Industrial Robot: 6-Axis Robots
C-C series Manual
Original instructions
© Seiko Epson Corporation 2025
Rev.2
ENM256R7471F
Table of Contents
1. Introduction
8
1.1 Introduction
9
1.2 Trademarks
9
1.3 Terms of Use
9
1.4 Manufacturer
9
1.5 Contact Information
9
1.6 Disposal
10
1.7 Before Use
10
1.8 Manual Types for This Product
10
2. C8 Manipulator
12
2.1 Safety
13
2.1.1 Conventions Used in This Manual
13
2.1.2 Design and Installation Safety
13
2.1.3 Operation Safety
14
2.1.4 Emergency Stop
15
2.1.5 Safeguard (SG)
15
2.1.6 How to Move Arms with the Electromagnetic Brake
16
2.1.6.1 When using a brake release unit
17
2.1.6.2 When using software
17
2.1.7 Precaution for Operation in Low Power Status
18
2.1.8 Warning Labels
18
2.1.8.1 Warning Labels
18
2.1.8.2 Information Labels
19
2.1.9 Responses for Emergencies or Malfunctions
20
2.1.9.1 When a Collision with the Manipulator Occurs
20
2.1.9.2 Entanglement with the Manipulator
20
2.2 Specifications
20
2.2.1 Model Number
20
2.2.2 Part Names and Motion Range of Each Arm
22
2.2.3 Outer Dimensions
24
2.2.3.1 C8-C901*** (C8L)
24
2.2.3.2 C8-C1401*** (C8L)
25
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
2
2.2.4 Standard Work Envelope
26
2.2.4.1 C8-C901*** (C8L)
26
2.2.4.2 C8-C1401*** (C8XL)
29
2.2.5 Specifications
30
2.2.5.1 Specifications Table
30
2.2.5.2 Options
30
2.2.6 How to Set the Model
30
2.3 Environment and Installation
31
2.3.1 Environment
31
2.3.2 Manipulator Mounting Dimensions
32
2.3.2.1 Cable backward model
33
2.3.2.2 Cable downward model
34
2.3.3 From Unpacking to Installation
35
2.3.4 Connecting the Cables
39
2.3.5 User Wires and Pneumatic Tubes
40
2.3.5.1 Electrical Wires
42
2.3.5.2 Pneumatic Tubes
43
2.3.6 Checking the Basic Orientation
44
2.3.7 Relocation and Storage
45
2.3.7.1 Safety Information for Relocation and Storage
45
2.4 Setting the Hand
48
2.4.1 Installing the Hand
48
2.4.2 Attaching Cameras and Valves
49
2.4.3 WEIGHT and INERTIA Settings
51
2.4.3.1 WEIGHT Setting
54
2.4.3.2 INERTIA Setting
57
2.4.4 Safety Information for Auto Acceleration
60
2.5 Work Envelope
61
2.5.1 Work Envelope Setting by Pulse Range (for Each Joint)
61
2.5.1.1 Joint #1 Maximum Pulse Range
62
2.5.1.2 Joint #2 Maximum Pulse Range
62
2.5.1.3 Joint #3 Maximum Pulse Range
63
2.5.1.4 Joint #4 Maximum Pulse Range
63
2.5.1.5 Joint #5 Maximum Pulse Range
63
2.5.1.6 Joint #6 Maximum Pulse Range
64
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
3
2.5.2 Setting the Work Envelope by Mechanical Stops
64
2.5.2.1 Setting the Joint #1 Work Envelope
65
2.5.2.2 Setting the Joint #2 Work Envelope
65
2.5.2.3 Setting the Joint #3 Work Envelope
66
2.5.3 Restriction of Manipulator Operation by Joint Angle Combination
67
2.5.4 Coordinate System
68
2.5.5 Changing the Robot
70
2.5.6 Setting the Rectangular Range in the XY Coordinate System of the Manipulator
71
2.6 Options
71
2.6.1 Brake Release Unit
71
2.6.1.1 Power Cable
72
2.6.1.2 Installing the Brake Release Unit
74
2.6.1.3 Removing the Brake Release Unit
74
2.6.1.4 How to Use the Brake Release Unit
74
2.6.2 Camera Plate Unit
75
2.6.3 Tool Adapter (ISO flange)
77
2.6.4 Variable Mechanical Stop
79
2.6.5 User Wires and Pneumatic Tubes
80
3. C12 Manipulator
81
3.1 Safety
82
3.1.1 Conventions Used in This Manual
82
3.1.2 Design and Installation Safety
82
3.1.3 Operation Safety
83
3.1.4 Emergency Stop
84
3.1.5 Safeguard (SG)
84
3.1.6 How to Move Arms with the Electromagnetic Brake
85
3.1.6.1 When using a brake release unit
86
3.1.6.2 When using software
86
3.1.7 Precaution for Operation in Low Power Status
87
3.1.8 Warning Labels
87
3.1.8.1 Warning Labels
87
3.1.8.2 Information Labels
88
3.1.9 Responses for Emergencies or Malfunctions
89
3.1.9.1 When a Collision with the Manipulator Occurs
89
3.1.9.2 Entanglement with the Manipulator
89
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
4
3.2 Specifications
89
3.2.1 Model Number
89
3.2.2 Part Names and Motion Range of Each Arm
90
3.2.3 Outer Dimensions
93
3.2.4 Standard Work Envelope
94
3.2.5 Specifications
95
3.2.5.1 Specifications Table
95
3.2.5.2 Options
95
3.2.6 How to Set the Model
95
3.3 Environment and Installation
96
3.3.1 Environment
96
3.3.2 Manipulator Mounting Dimensions
97
3.3.2.1 Cable backward model
98
3.3.2.2 Cable downward model
99
3.3.3 From Unpacking to Installation
99
3.3.4 Connecting the Cables
103
3.3.5 User Wires and Pneumatic Tubes
104
3.3.5.1 Electrical Wires
105
3.3.5.2 Pneumatic Tubes
106
3.3.6 Checking the Basic Orientation
107
3.3.7 Relocation and Storage
108
3.3.7.1 Safety Information for Relocation and Storage
108
3.4 Setting the Hand
110
3.4.1 Installing the Hand
110
3.4.2 Attaching Cameras and Valves
112
3.4.3 WEIGHT and INERTIA Settings
112
3.4.3.1 WEIGHT Setting
115
3.4.3.2 INERTIA Setting
117
3.4.4 Safety Information for Auto Acceleration
121
3.5 Work Envelope
122
3.5.1 Work Envelope Setting by Pulse Range (for Each Joint)
122
3.5.1.1 Joint #1 Maximum Pulse Range
123
3.5.1.2 Joint #2 Maximum Pulse Range
123
3.5.1.3 Joint #3 Maximum Pulse Range
123
3.5.1.4 Joint #4 Maximum Pulse Range
124
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
5
3.5.1.5 Joint #5 Maximum Pulse Range
124
3.5.1.6 Joint #6 Maximum Pulse Range
124
3.5.2 Setting the Work Envelope by Mechanical Stops
125
3.5.2.1 Setting the Joint #1 Work Envelope
125
3.5.2.2 Setting the Joint #2 Work Envelope
126
3.5.2.3 Setting the Joint #3 Work Envelope
126
3.5.3 Restriction of Manipulator Operation by Joint Angle Combination
127
3.5.4 Coordinate System
127
3.5.5 Changing the Robot
128
3.5.6 Setting the Rectangular Range in the XY Coordinate System of the Manipulator
129
3.6 Options
129
3.6.1 Brake Release Unit
130
3.6.1.1 Power Cable
131
3.6.1.2 Installing the Brake Release Unit
132
3.6.1.3 Removing the Brake Release Unit
132
3.6.1.4 How to Use the Brake Release Unit
132
3.6.2 Camera Plate Unit
133
3.6.3 Tool Adapter (ISO flange)
136
3.6.4 Variable Mechanical Stop
137
3.6.5 User Wires and Pneumatic Tubes
138
4. Periodic Inspection
140
4.1 C8 Manipulator Periodic Inspection
141
4.1.1 Inspection
141
4.1.1.1 Inspection Schedule
141
4.1.1.2 Inspection Details
142
4.1.2 Overhaul (Parts Replacement)
143
4.1.3 Applying Grease
143
4.1.4 Tightening the Hexagon Socket Head Cap Bolts
144
4.2 C12 Manipulator Periodic Inspection
145
4.2.1 Inspection
145
4.2.1.1 Inspection Schedule
145
4.2.1.2 Inspection Details
146
4.2.2 Overhaul (Parts Replacement)
147
4.2.3 Applying Grease
148
4.2.4 Tightening the Hexagon Socket Head Cap Bolts
148
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
6
5. Appendix 150
5.1 Appendix A: Specifications Table
151
5.1.1 C8 Specifications
151
5.1.2 C12 Specifications
157
5.2 Appendix B: Stopping Time and Stopping Distance at Emergency Stop
162
5.2.1 C8-C Stopping Time and Stopping Distance at Emergency Stop
164
5.2.2 C12-C Stopping Time and Stopping Distance at Emergency Stop
170
5.2.3 Supplementary Information regarding the Stopping Time and Stopping Distance at Emergency Stop
173
5.2.3.1 How to check the stopping time and stopping distance in the customer’s environment
173
5.2.3.2 Commands that can be useful when measuring stopping time and stopping distance
174
5.3 Appendix C: Stopping Time and Stopping Distance When Safeguard is Open
174
5.3.1 C8-C Stopping Time and Stopping Distance When Safeguard is Open
176
5.3.2 C12-C Stopping Time and Stopping Distance When Safeguard is Open
182
5.3.3 Supplementary Information regarding the Stopping Time and Stopping Distance when the Safeguard is
Open
184
5.3.3.1 How to check the stopping time and stopping distance in the customer’s environment
184
5.3.3.2 Commands that can be useful when measuring stopping time and stopping distance
185
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
7
1. Introduction
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
8
1.1 Introduction
Thank you for purchasing this Epson robot system. This manual provides the information necessary for correctly using the
robot system.
Before using the system, please read this manual and related manuals to ensure correct use.
After reading this manual, store it in an easily accessible location for future reference.
Epson conducts rigorous testing and inspection to ensure that the performance of our robot systems meets our standards. Please
note that if the Epson robot system is used outside the operating conditions described in the manual, the product will not
perform up to its basic performance.
This manual describes potential hazards and problems that are foreseen. To use the Epson robot system safely and correctly, be
sure to follow the safety information contained in this manual.
1.2 Trademarks
Microsoft, Windows, and the Windows logo are either registered trademarks or trademarks of Microsoft Corporation in the
United States and/or other countries. All other company names, brand names, and product names are registered trademarks or
trademarks of their respective companies.
1.3 Terms of Use
No part of this instruction manual may be reproduced or reprinted in any form without express written permission.
The information in this document is subject to change without notice.
Please contact us if you find any errors in this document or if you have any questions about the information in this document.
1.4 Manufacturer
1.5 Contact Information
Contact information details are listed in the "Supplier" section in the following manual.
Note that the contact information may vary depending on your region.
"Safety Manual - Contact Information"
The Safety Manual is also available at the following site.
URL: https://download.epson.biz/robots/
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
9
1.6 Disposal
When disposing of this product, please do so in accordance with the laws and regulations of your country.
1.7 Before Use
Before using this manual, be sure that you understand the following information.
Control system configuration
The C-C series Manipulators are made up of a combination of the following Controller and software.
Manipulator Controller Software
C-C series RC800-A Epson RC+ 8.0
Setting from the software
This manual contains the procedures for configuring the settings from the software. Use of this software is indicated by the
above mark.
Controller power on (off)
In this manual, an instruction to "Turn on (off) the Controller power" means to turn on the power for the hardware that makes
up your Controller.
Images used in this manual
The photos and illustrations of the Manipulators shown in this manual may differ in shape and appearance from your
Manipulator due to the time it was shipped, specifications, and other factors.
1.8 Manual Types for This Product
This describes the typical types of manuals for this product and presents an overview of their content.
Safety Manual
This manual contains safety-related information intended for all people who use this product. It also guides the user
through the process from unpacking to usage and the manuals that should be referred to next. Please read this manual first.
Safety information and residual risks of robot systems
Declaration of Conformity
Training
Process from unpacking to usage
Robot Controller Safety Function Manual
This describes the procedures for configuring the safety functions of this product and the configuration software. It is
primarily intended for those who design robot systems.
RC800-A Manual
This manual describes the installation of the entire robot system and explains the specifications and functions of the
Controller. It is primarily intended for those who design robot systems.
Robot system installation procedure (specific details on the process from unpacking to usage)
Controller daily inspection points
Controller specifications and basic functions
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
10
C-C series Manual
This manual describes the specifications and functions of the Manipulator. It is primarily intended for those who design
robot systems.
Manipulator installation, technical information needed for design, function and specification tables, etc.
Manipulator daily inspection points
Status Code/Error Code List
This provides the code numbers displayed on the Controller and messages displayed in the message area of the software. It
is primarily intended for those who design and program robot systems.
Epson RC+ User's Guide
This manual presents an overview of the program development software.
Epson RC+ SPEL+ Language Reference
This manual explains the robot programming language SPEL+.
Other manuals
Manuals are available for each option.
Maintenance and servicing manuals
Manuals for maintenance and servicing are not included with the product. Maintenance should be performed by people who
have received maintenance training provided by Epson and the suppliers. For more information, please contact the supplier.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
11
2. C8 Manipulator
This chapter contains information for setup and operation of the Manipulators.
Please read this chapter thoroughly before setting up and operating the Manipulators.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
12
2.1 Safety
The Manipulator and its related equipment should be unpacked and transported by people who have received installation
training provided by Epson and the suppliers. Also, the laws and regulations of the installation country must be followed.
Before use, please read this manual and other related manuals to ensure correct use. After reading this manual, store it in an
easily accessible location for future reference.
This product is intended for transporting and assembling parts in a safely isolated area.
2.1.1 Conventions Used in This Manual
The following symbols are used in this manual to indicate important safety information. Be sure to read the descriptions shown
with each symbol.
WARNING
This symbol indicates an imminently hazardous situation which, if operation is not performed properly, will result
in death or serious injury.
WARNING
This symbol indicates a potentially hazardous situation which, if operation is not performed properly, could result
in an injury due to electric shock.
CAUTION
This symbol indicates a potentially hazardous situation which, if operation is not performed properly, may result in
a minor or moderate injury or in property damage only.
2.1.2 Design and Installation Safety
The robot system should be designed and installed by people who have received installation training provided by Epson and
the suppliers.
Design personnel should refer to the following manuals:
"Safety Manual"
"Controller Manual"
"Manipulator Manual"
Refer to the following section for the installation safety information.
Environment and Installation
Be sure to read this section and follow the safety information before installation to ensure that the installation work is
performed safely.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
13
2.1.3 Operation Safety
The following items are safety precautions for operating personnel:
WARNING
Be sure to read the Safety Manual before use. Operating the robot system without understanding the safety
information can be extremely dangerous and may result in serious injury or severe equipment damage.
Before operating the robot system, make sure that no one is inside the safety barriers. The robot system can
be operated in the teaching operation mode even when someone is inside the safety barriers. Even though
the motion of the Manipulator is always restricted (low speed and low power) to ensure operator safety, an
unexpected movement by the Manipulator can be extremely dangerous and may cause serious safety
problems.
If the Manipulator moves abnormally during operation of the robot system, immediately press the emergency
stop switch.
WARNING
To perform the power supply lockout, remove the power plug. Be sure to connect the AC power cable to a
power outlet. Do not connect it directly to a factory power source.
Before performing any replacement work, inform others in the area that you are working, and then turn off the
Controller and related equipment, and unplug the power cable from the power source. Performing any work
procedure with the power turned on is extremely dangerous and may result in electric shock and/or
malfunction of the robot system.
Do not connect or disconnect the connector of the M/C cable while the Controller is turned on. There is a risk
the Manipulator may malfunction, which is extremely hazardous. Also, performing any work procedure with
the power turned on may result in electric shock and/or malfunction of the robot system.
CAUTION
Whenever possible, only one person should operate the robot system. If it is necessary to operate with more
than one person, ensure that all personnel communicate with each other and take all necessary safety
precautions.
If the Manipulator is operated repeatedly with each joint having an operating angle of 5° or less, the bearings
used in the joints are likely to cause oil film shortage. Repeated operation may cause premature damage. To
prevent premature damage, operate the Manipulator to move each joint to an angle of 30° or more about
once per hour.
When the robot is operating at low speed (Speed: 5 to 20%), vibration (resonance) may occur continuously
during operation depending on the combination of the arm orientation and hand load. Vibration occurs due to
the natural vibration frequency of the arm and can be reduced by taking the following measures:
Changing the robot speed
Changing the teach points
Changing the hand load
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
14
2.1.4 Emergency Stop
Each robot system needs equipment that will allow the operator to immediately stop the system's operation. Install an
emergency stop device by using emergency stop input from the Controller or other equipment.
Before using the emergency stop switch, be aware of the following points.
The emergency stop switch should be used to stop the Manipulator only in case of emergencies.
Besides pressing the emergency stop switch when an emergency occurs, to stop the Manipulator during program operation,
use the Pause or STOP (program stop) statements assigned to a standard I/O.
The Pause and STOP statements do not turn off motor energization, and so the brake is not locked.
To place the robot system in emergency stop mode in a non-emergency (normal) situation, press the emergency stop switch
while the Manipulator is not operating.
Do not press the emergency stop switch unnecessarily while the Manipulator is operating normally.
It could shorten the lifespan of the following components.
Brakes
The brakes will be locked, which will shorten the lifespan of the brakes due to worn brake friction plates.
Normal brake lifespan:
About 2 years (when the brakes are used 100 times/day)
or about 20,000 times
Reduction gears
An emergency stop applies an impact to the reduction gear, which can shorten its life.
If the Manipulator is stopped by turning off the Controller while it is operating, the following problems may occur.
Reduced life and damage to reduction gear
Position shift at the joints
If a power outage or other unavoidable Controller power-off occurs during Manipulator operation, check the following points
after power is restored.
Damage in reduction gear
Shifting of the joints from their proper positions
If there was any shifting, maintenance is required. For more information, please contact the supplier.
Stopping distance of emergency stop
The Manipulator during operation cannot stop immediately after the emergency stop switch is pressed. Also, the stopping time
and movement distance vary depending on the following factors.
Hand weight, WEIGHT setting, ACCEL setting, workpiece weight, SPEED setting, movement posture, etc.
For the stopping time and movement distance of the Manipulator, refer to the following section.
Appendix B: Stopping Time and Stopping Distance at Emergency Stop
2.1.5 Safeguard (SG)
To maintain a safe working zone, safety barriers must be set up around the Manipulator, and safeguards must be installed at the
entrance and exit of the safety barriers.
The term "safeguard" as used in this manual refers to a safety device with an interlock that allows entry into the safety barriers.
Specifically, this includes safety door switches, safety barriers, light curtains, safety gates, safety floor mats, and so on. The
safeguard is an input that informs the Robot Controller that an operator may be inside the safeguard area. You must assign at
least one Safeguard (SG) in Safety Function Manager.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
15
When the safeguard is opened, Protective Stop operates to change to the safeguard open state (display: SO).
Safeguard open
Operations are prohibited. Further robot operation is not possible until either the safeguard is closed, the latched state is
released, and a command is executed, or the TEACH or TEST operation mode is turned on and the enable circuit is
activated.
Safeguard closed
The robot can operate automatically in an unrestricted (high power) state.
WARNING
If a third party accidentally releases the safeguard while an operator is working inside the safety barriers, this
may result in a hazardous situation. To protect the operator working inside the safety barriers, implement
measures to lock out or tag out the latch release switch.
To protect operators working near the robot, be sure to connect a safeguard switch and make sure that it
works properly.
Installing safety barriers
When installing safety barriers within the maximum range of the Manipulator, combine safety functions such as SLP. Carefully
take into account the size of the hand and the workpieces to be held so that no interference occurs between the operating parts
and the safety barriers.
Installing safeguards
Design the safeguards so that they satisfy the following requirements:
When using a key switch type safety device, use a switch that forcibly opens the interlock contacts. Do not use switches
that open their contacts using the spring force of the interlock.
When using an interlock mechanism, do not disable the interlock mechanism.
Considering the stopping distance
During operation, the Manipulator cannot stop immediately even if the safeguard is opened. Also, the stopping time and
movement distance vary depending on the following factors.
Hand weight, WEIGHT setting, ACCEL setting, workpiece weight, SPEED setting, movement posture, etc.
For the stopping time and movement distance of the Manipulator, refer to the following section.
Appendix C: Stopping Time and Stopping Distance When Safeguard is Open
Precautions for safeguard operation
Do not open the safeguard unnecessarily while the motor is energized. Frequent safeguard inputs will reduce the life of the
relay.
Normal relay lifespan: About 20,000 times
2.1.6 How to Move Arms with the Electromagnetic Brake
There are two methods to release the electromagnetic brake. Follow either method to release the electromagnetic brake and
move the arms manually.
When using a brake release unit
Follow the method when you just unpack the delivered boxes or when the Controller does not start up yet.
When using software
Follow the method when you can use the software.
While the electromagnetic brake is on (such as in emergency mode), you cannot move any arm by pushing manually.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
16
Arm Motion
2.1.6.1 When using a brake release unit
This series has the Brake Release Unit as an option. For details, refer to the following section.
Options
2.1.6.2 When using software
CAUTION
Normally, release the brakes of joints one at a time. If the brakes of two or more joints must be released
simultaneously due to unavoidable reasons, use extreme care. Releasing the brakes of multiple joints
simultaneously may cause the arm to fall in an unexpected direction, resulting in hands or fingers getting
caught or damage or failure of the Manipulator.
After releasing the brake, the arm may fall by its own weight or move to the unexpected direction. Make sure
to prepare a countermeasure to prevent the arm from falling and check the operation environment is safe.
Before releasing the brake, be sure to keep the emergency stop switch in an easily accessible location so that
you can immediately press it if necessary. Otherwise, if the emergency stop switch is not easily accessible,
you will be unable to immediately stop the arm falling due to an erroneous operation, which could lead to
Manipulator damage or breakdown.
After releasing the Emergency Stop switch, execute the following command in [Command Window].
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
17
>Reset
>Brake Off,[The number (from 1 to 6) corresponding to the arm whose brake will be
turned off]
Execute the following command to turn on the brake again.
>Brake On,[The number (from 1 to 6) corresponding to the arm whose brake will be
turned on]
2.1.7 Precaution for Operation in Low Power Status
In the low power status, the Manipulator operates at low speed and low torque. However, comparatively high torque as shown
in the table below may be generated to support the Manipulator’s own weight. Carefully operate the Manipulator since it may
get your hands or fingers caught during operation. The Manipulator may also collide with peripheral equipment and cause
equipment damage to or malfunction of the Manipulator.
Maximum Joint Torque in Low Power Status [Unit: N·m]
Joint #1 #2 #3 #4 #5 #6
Joint Torque
C8-C901*** (C8L) 172.10
300.96 129.34 34.97 39.96 20.54
C8-C901**W (C8L) 452.88
C8-C1401*** (C8XL) 449.79
731.34 373.31 52.45 59.94 30.81
C8-C1401**W (C8XL) 719.66
CAUTION
Carefully operate the Manipulator in the low power status. A comparatively high joint torque may be
generated. It may cause your hands and fingers caught and/or cause equipment damage to or malfunction of
the Manipulator as it may collide with peripheral equipment.
2.1.8 Warning Labels
The Manipulator has the following warning labels. Specific hazards exist in the vicinity of areas with the warning labels. Be
thoroughly careful in handling. To ensure that the Manipulator is operated and maintained safely, be sure to follow the safety
information and warnings indicated on the warning labels. Also, do not tear, damage, or remove these warning labels.
2.1.8.1 Warning Labels
A
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
18
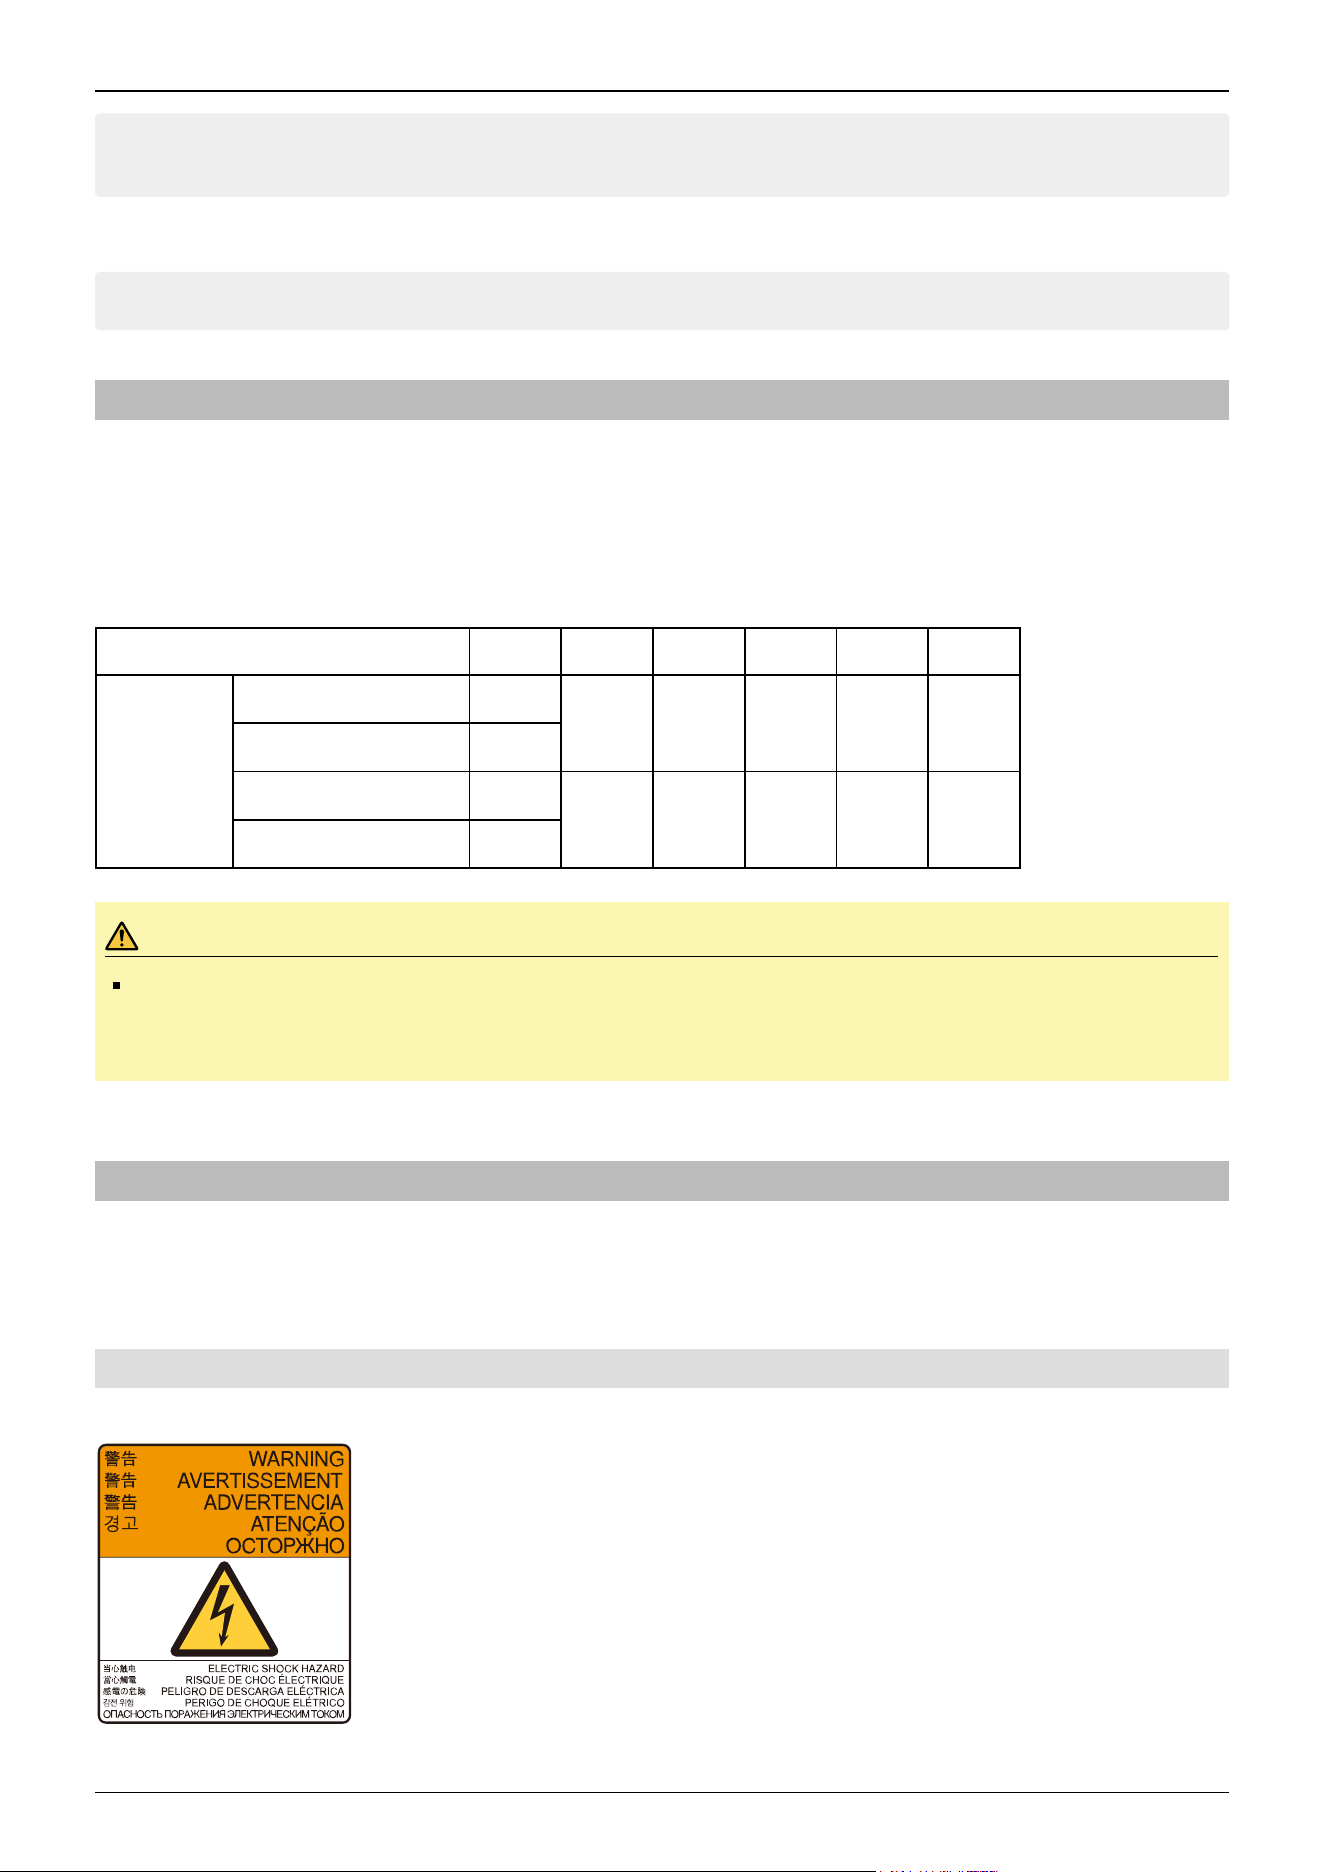
Touching any internal electrified parts while the power is turned on may cause electric shock.
B
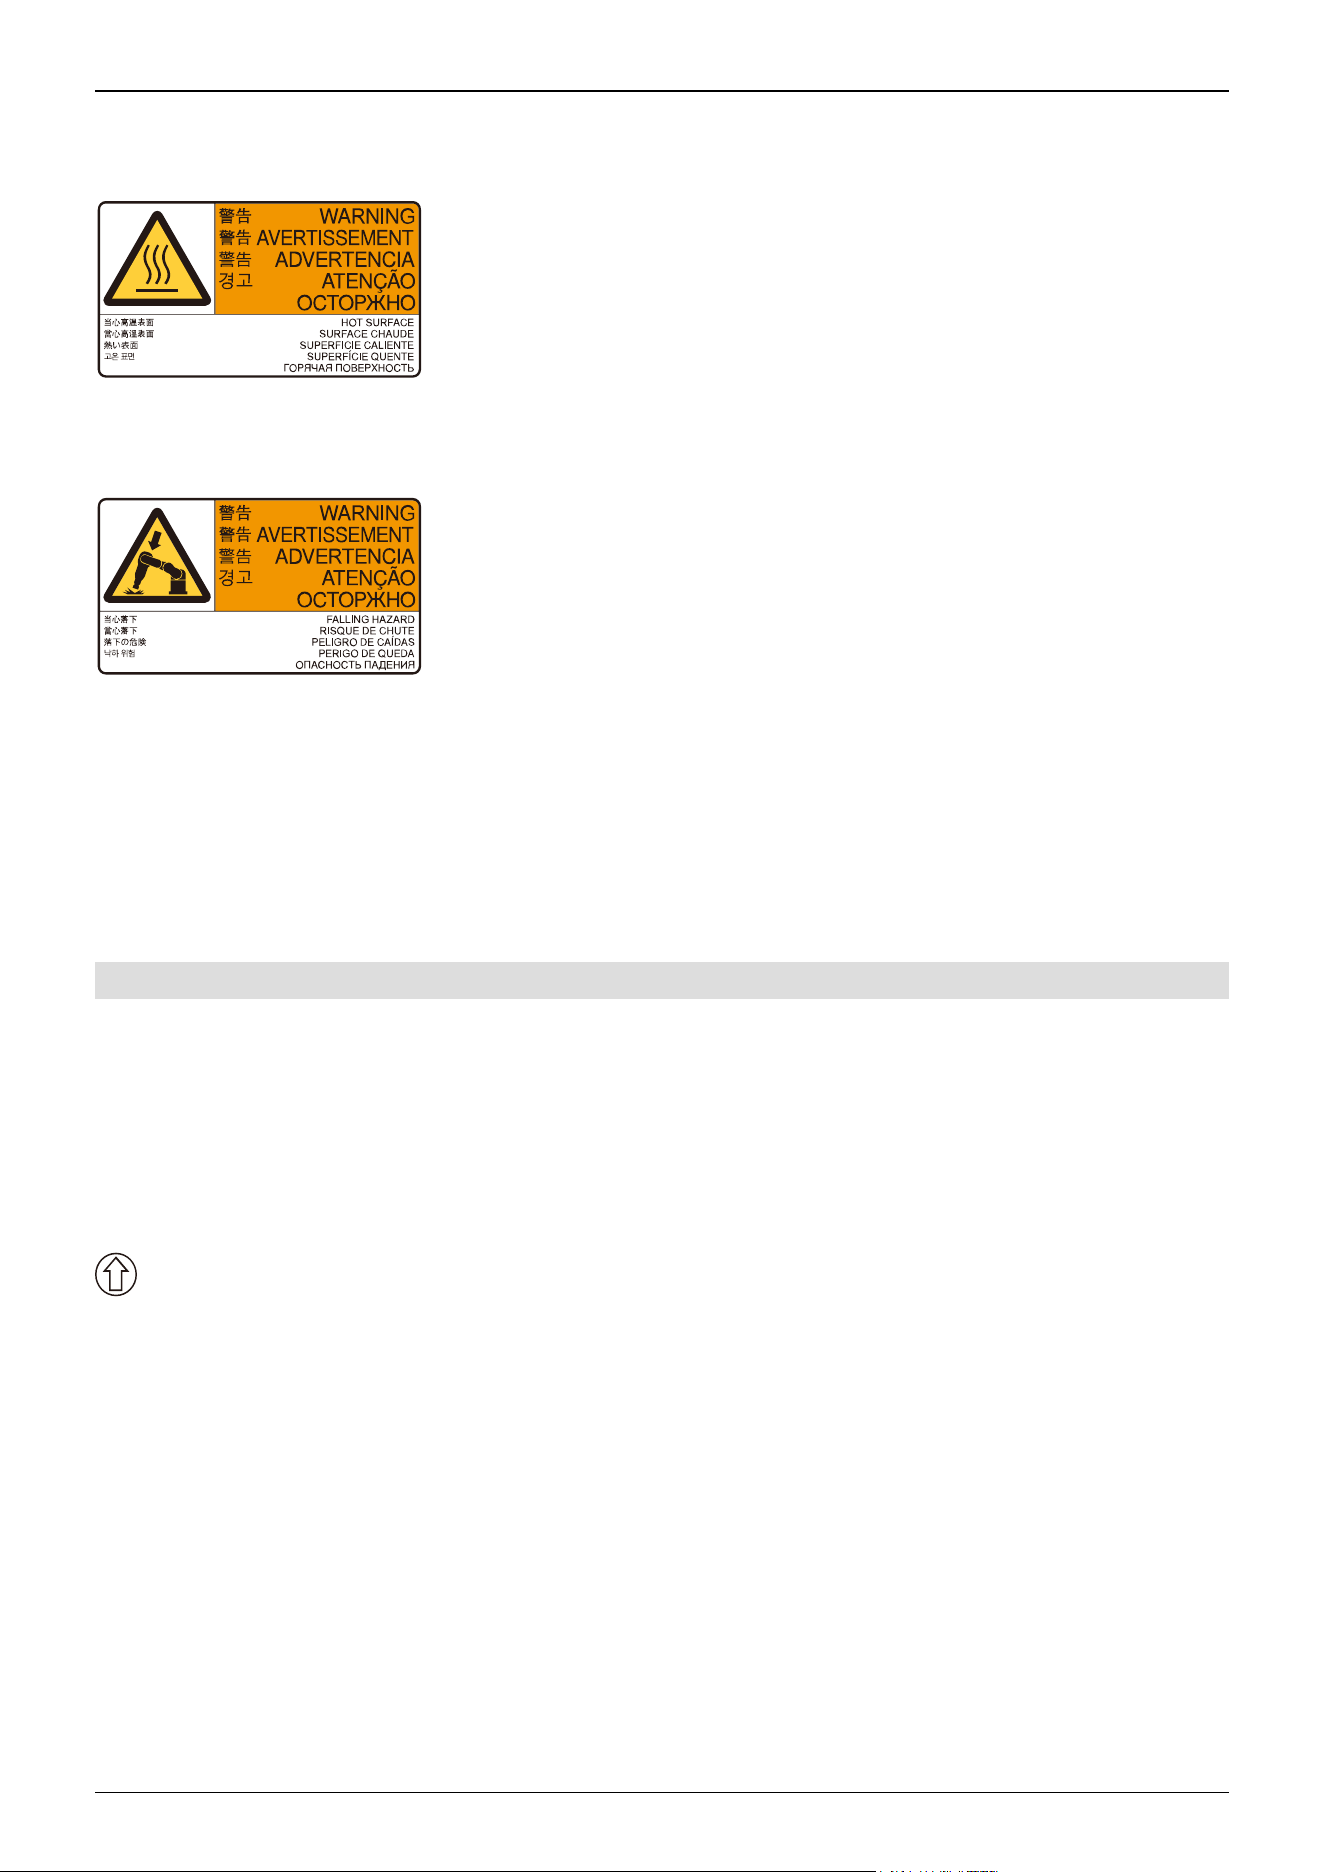
HOT Be careful not to burn yourself.
C
When releasing the brakes, be careful of the arm falling due to its own weight.
This warning label is attached on the Manipulator and optional brake release unit as well.
When the brake release unit is used:
When using a brake release unit to release brakes, refer to the following section.
How to Move Arms with the Electromagnetic Brake
2.1.8.2 Information Labels
1
This indicates the product name, model name, serial number, information of supported laws and regulations, product
specifications (Weight, MAX.REACH, MAX.PAYLOAD, AIR PRESSURE, Motor Power), Main document No.,
manufacturer, importer, date of manufacture, country of manufacture, and the like.
For details, see the label affixed to the product.
2
This indicates the position for mounting eyebolts. Refer to the following section for examples of using eyebolts.
Environment and Installation
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
19
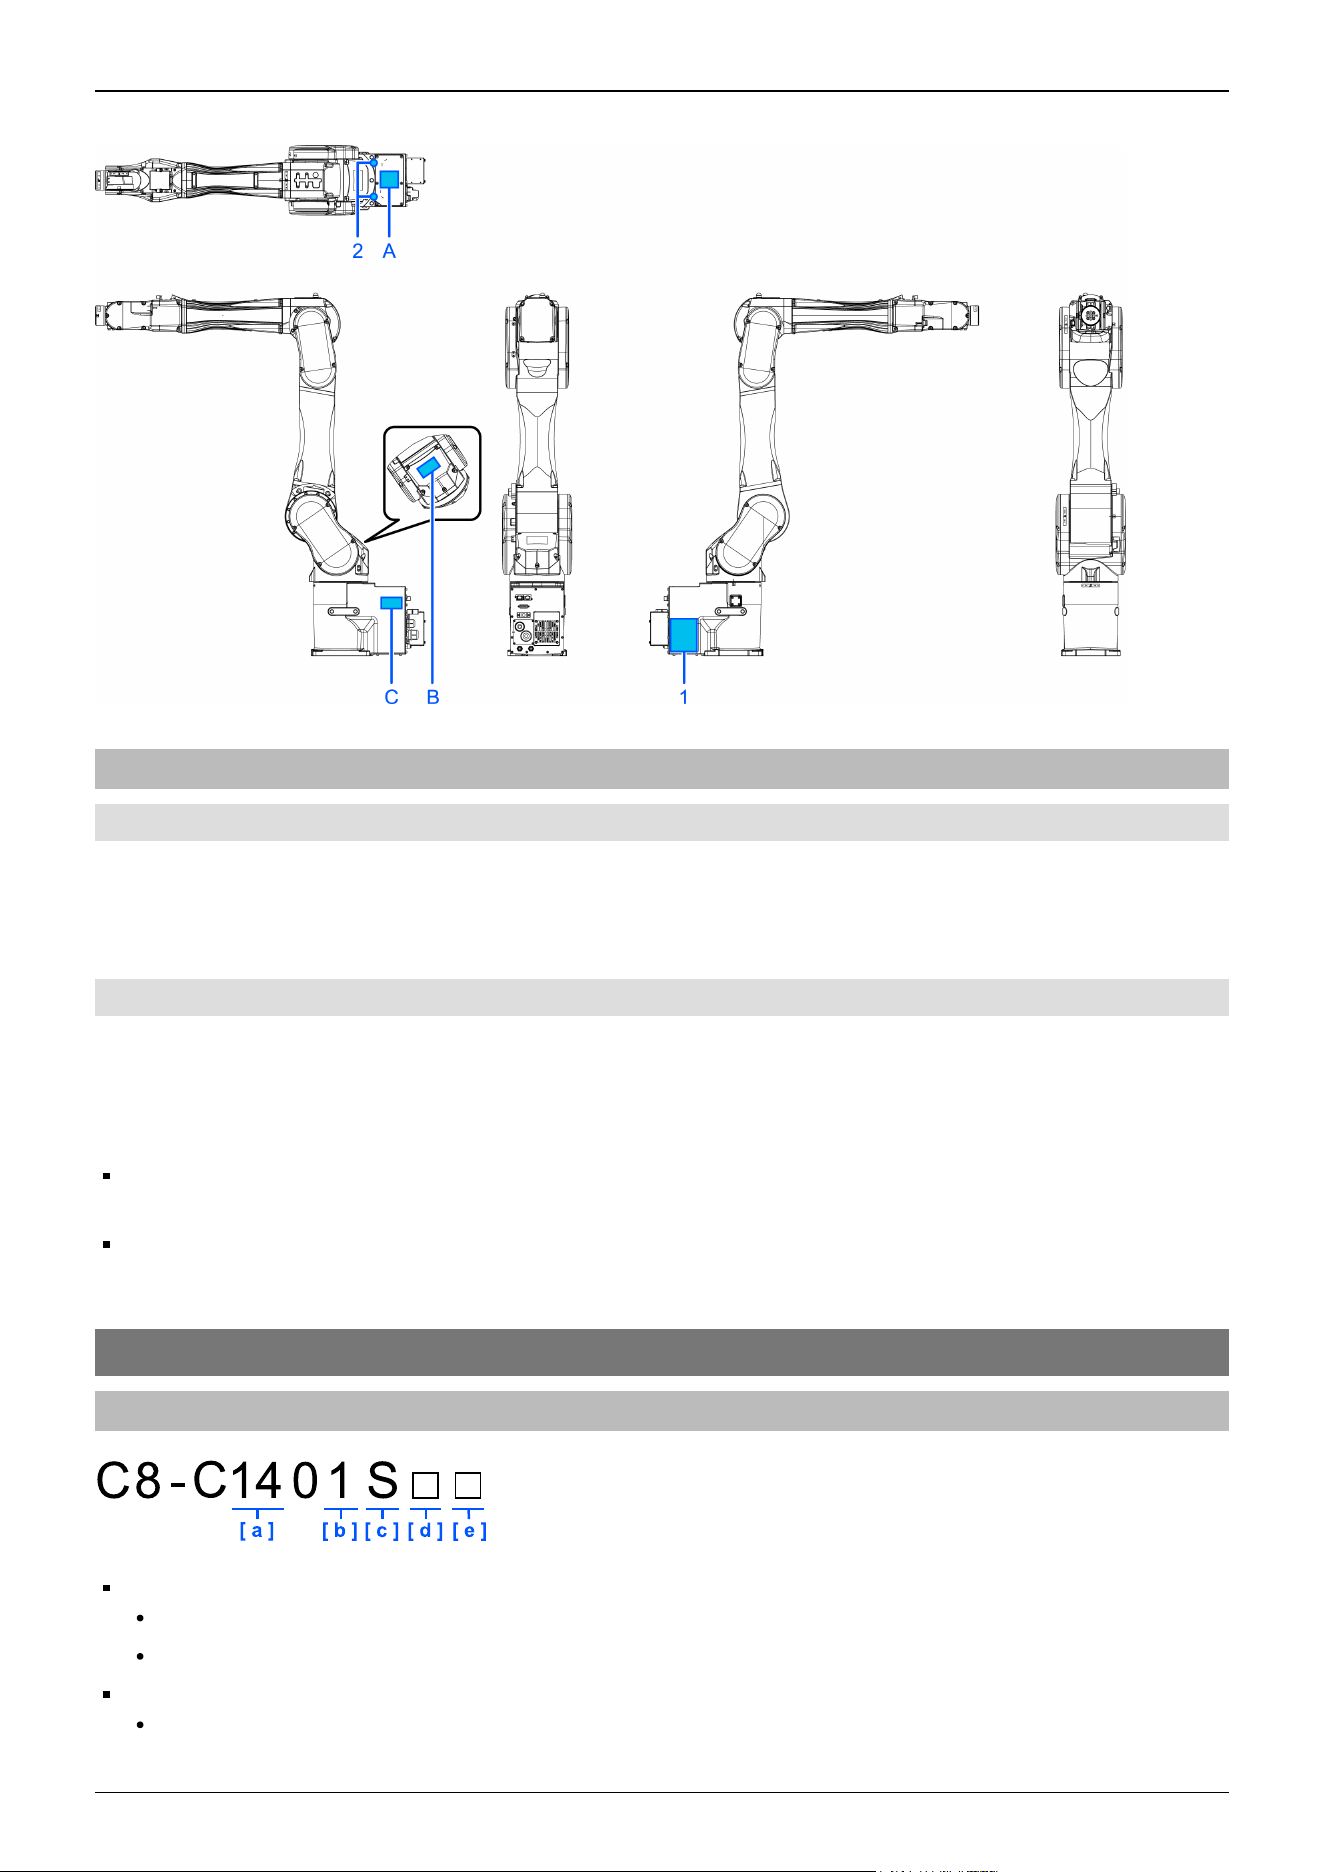
Location of Labels
2.1.9 Responses for Emergencies or Malfunctions
2.1.9.1 When a Collision with the Manipulator Occurs
If the Manipulator has collided with a mechanical stop, peripheral device, or other object, discontinue use and contact the
supplier.
2.1.9.2 Entanglement with the Manipulator
When the operator is caught between the Manipulator and a mechanical part such as a base table, press the emergency stop
switch to release the brake on the subject arm, and then move the arm by hand.
How to release a brake
When using a brake release unit, refer to the following section.
Brake Release Unit
When using software, refer to the following section.
When using software
2.2 Specifications
2.2.1 Model Number
a: Arm length
9: 900 mm (Model name: C8L)
14: 1400 mm (Model name: C8XL)
b: Brake equipment
1: Brakes on all joints
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
20
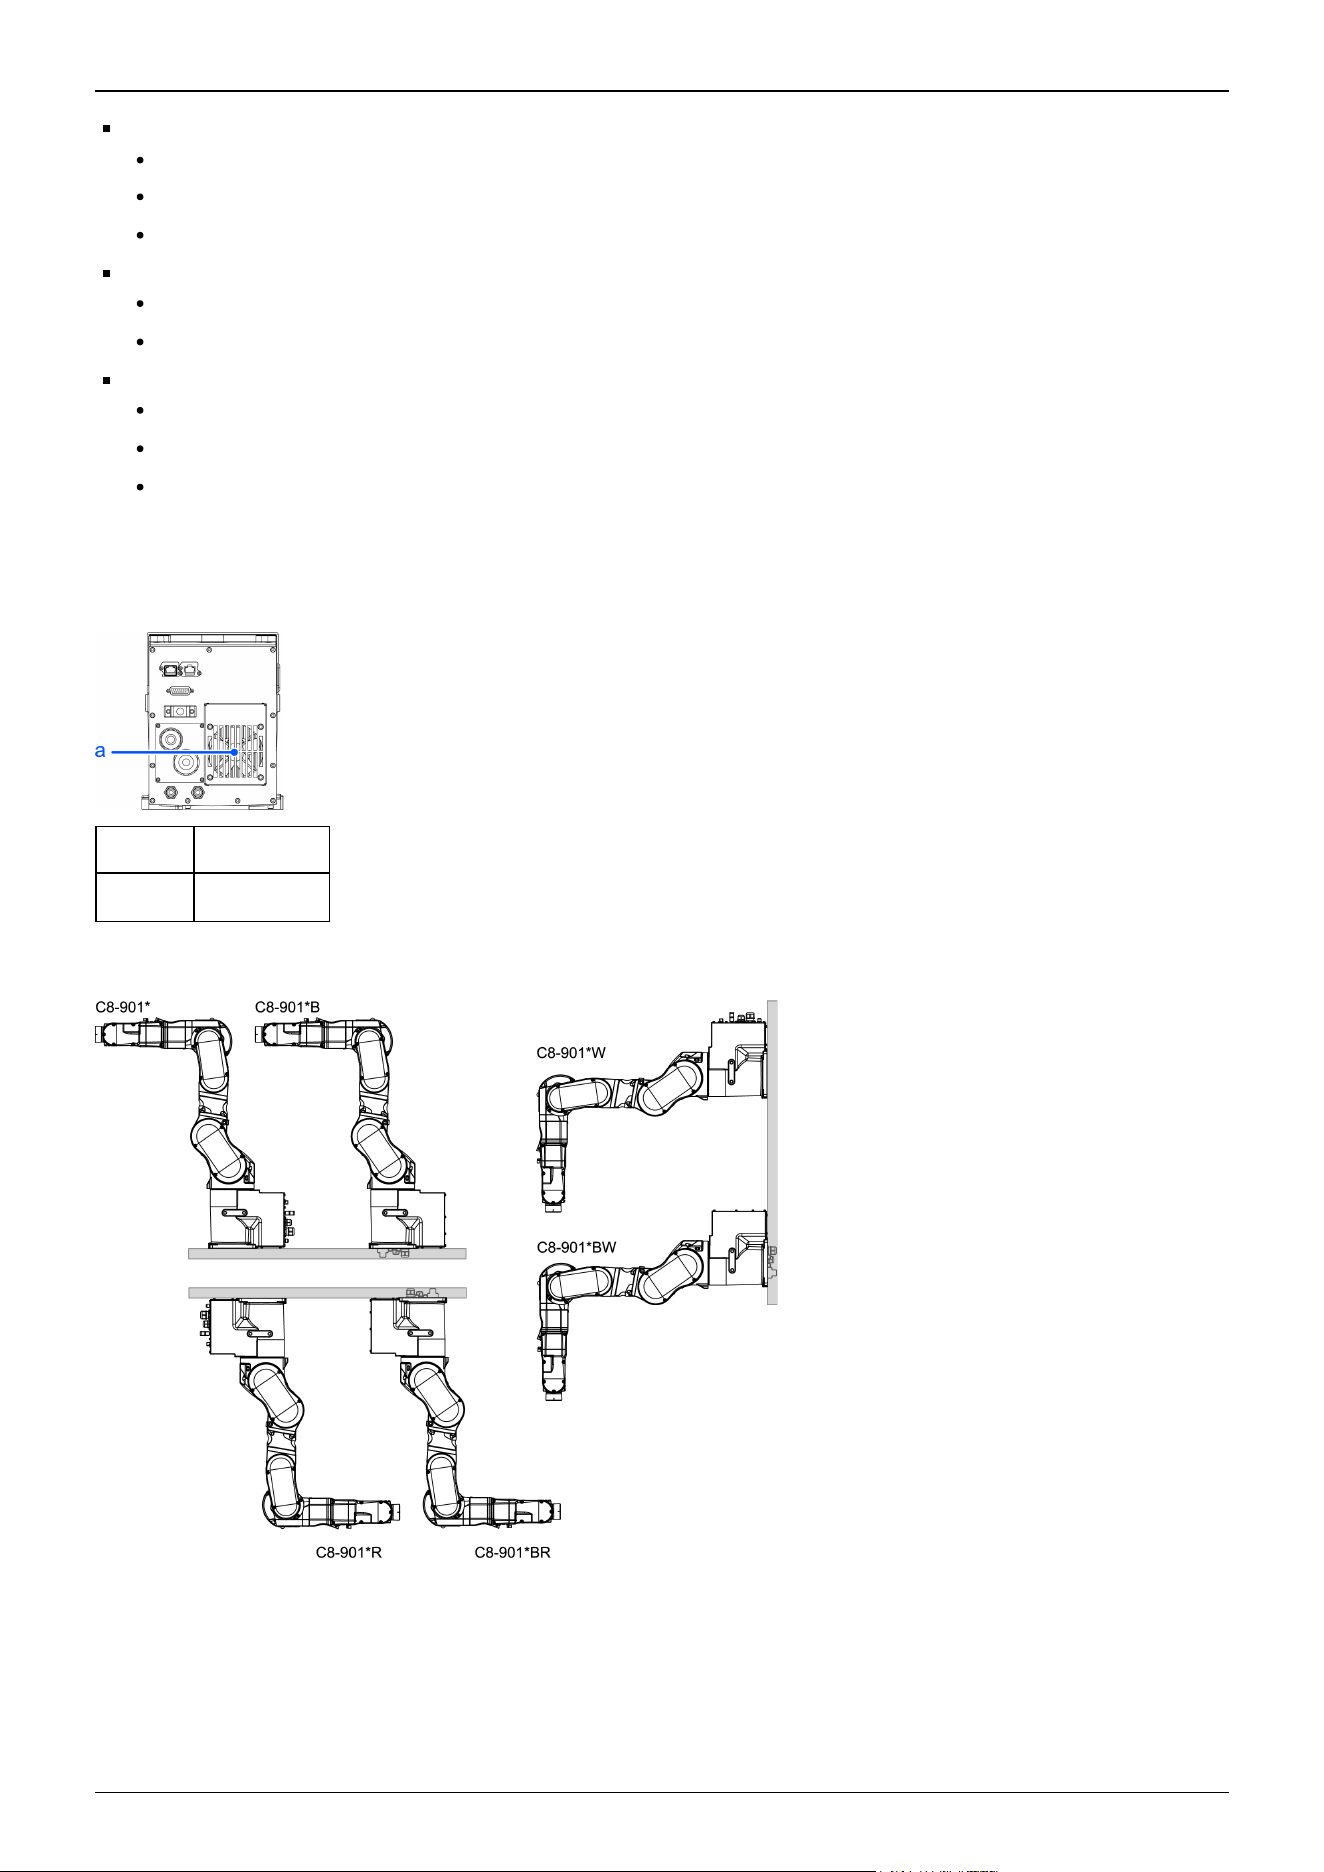
c: Environment
S: Standard *1
C: Cleanroom & ESD (anti-static) *1
P: Protection *2
d: M/C cable installation direction
□: Cable backward
B: Cable downward
e: Mounting type
□: Table top mounting
R: Ceiling mounting
W: Wall mounting
*1 Equivalent to IP20
*2 IP67 (fan cover: equivalent to IP20)
Symbol Description
a Fan cover
Example
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
21
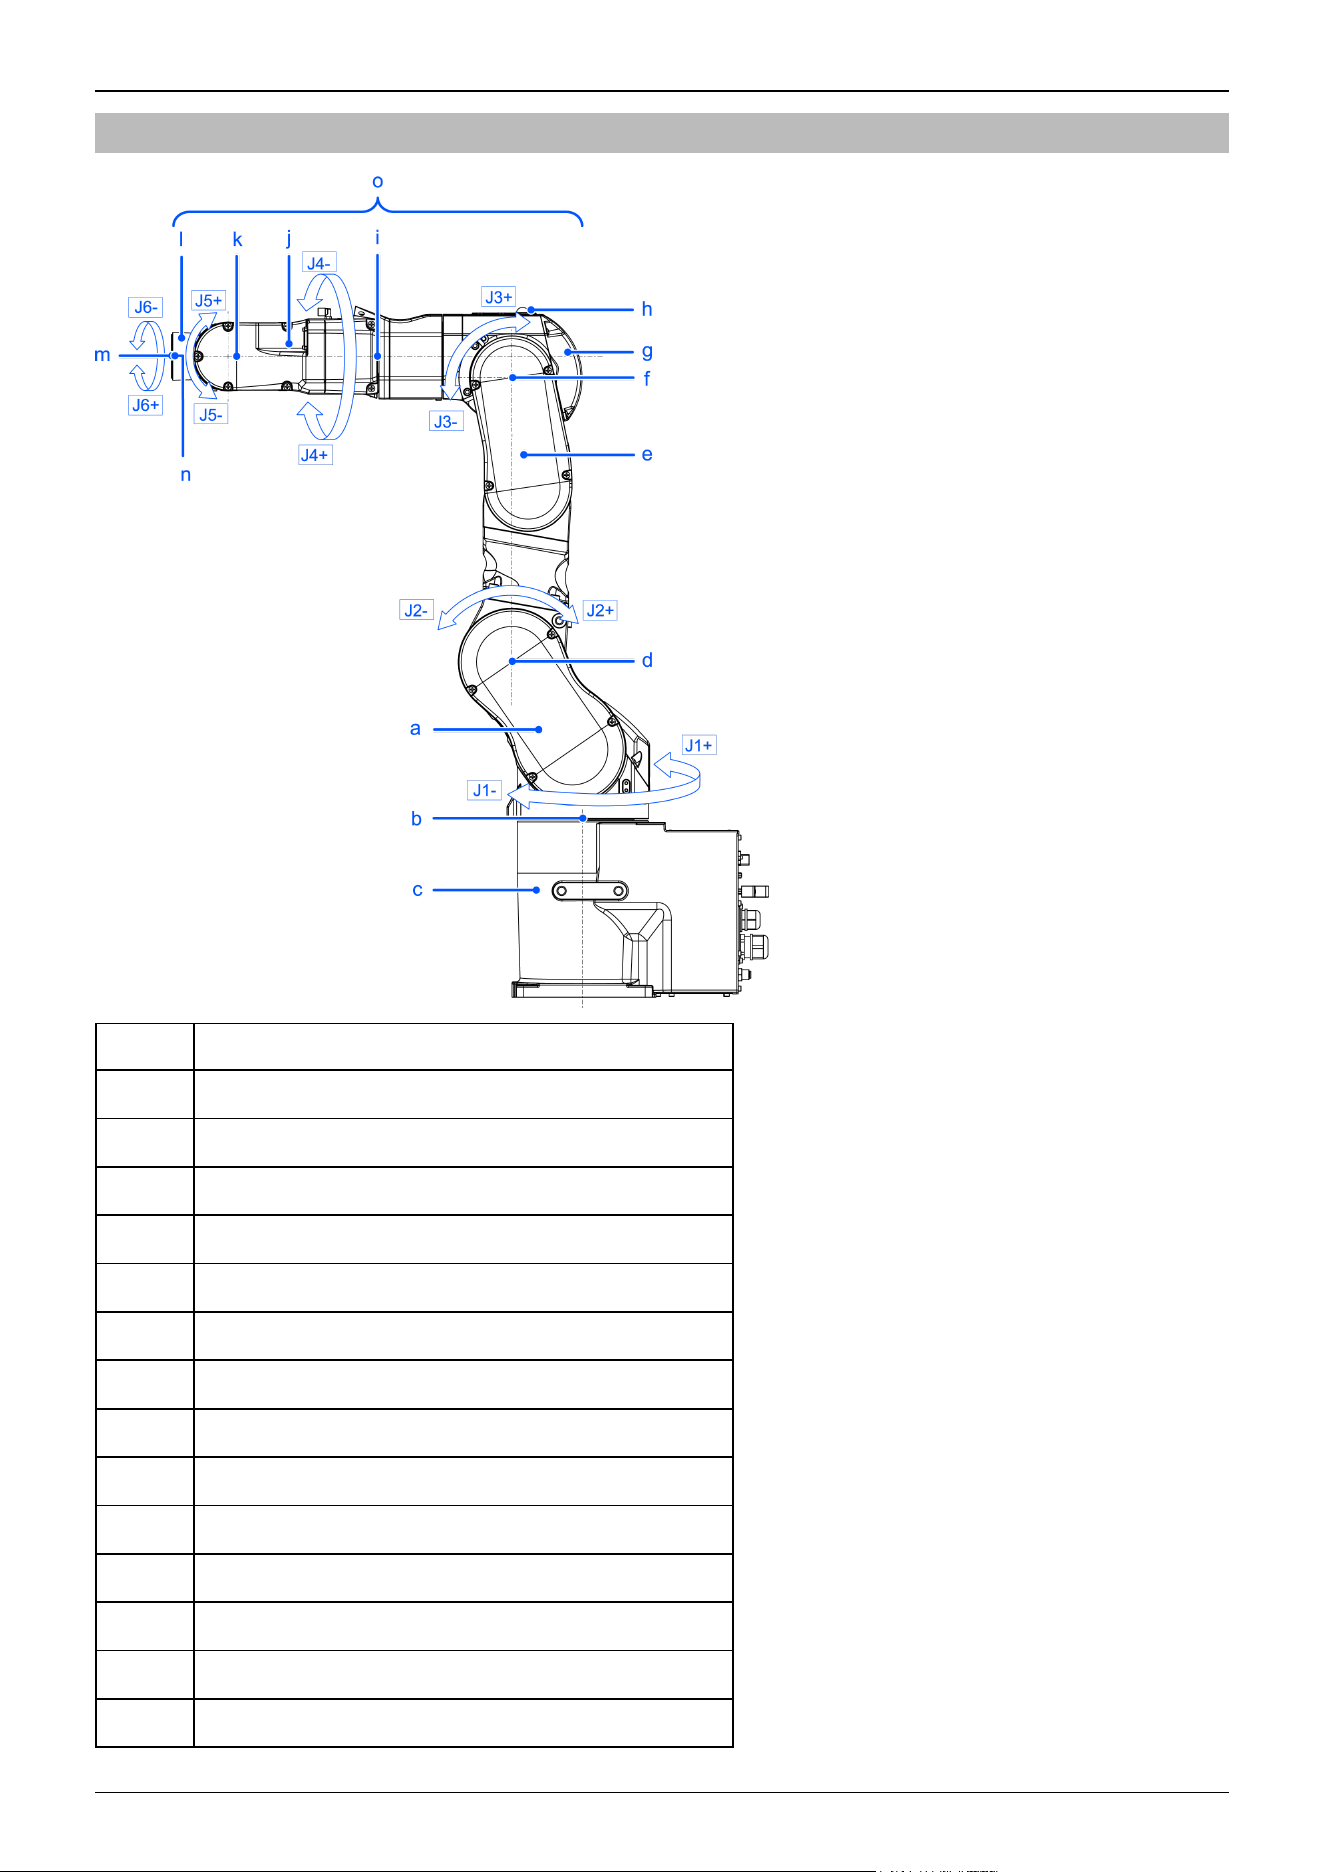
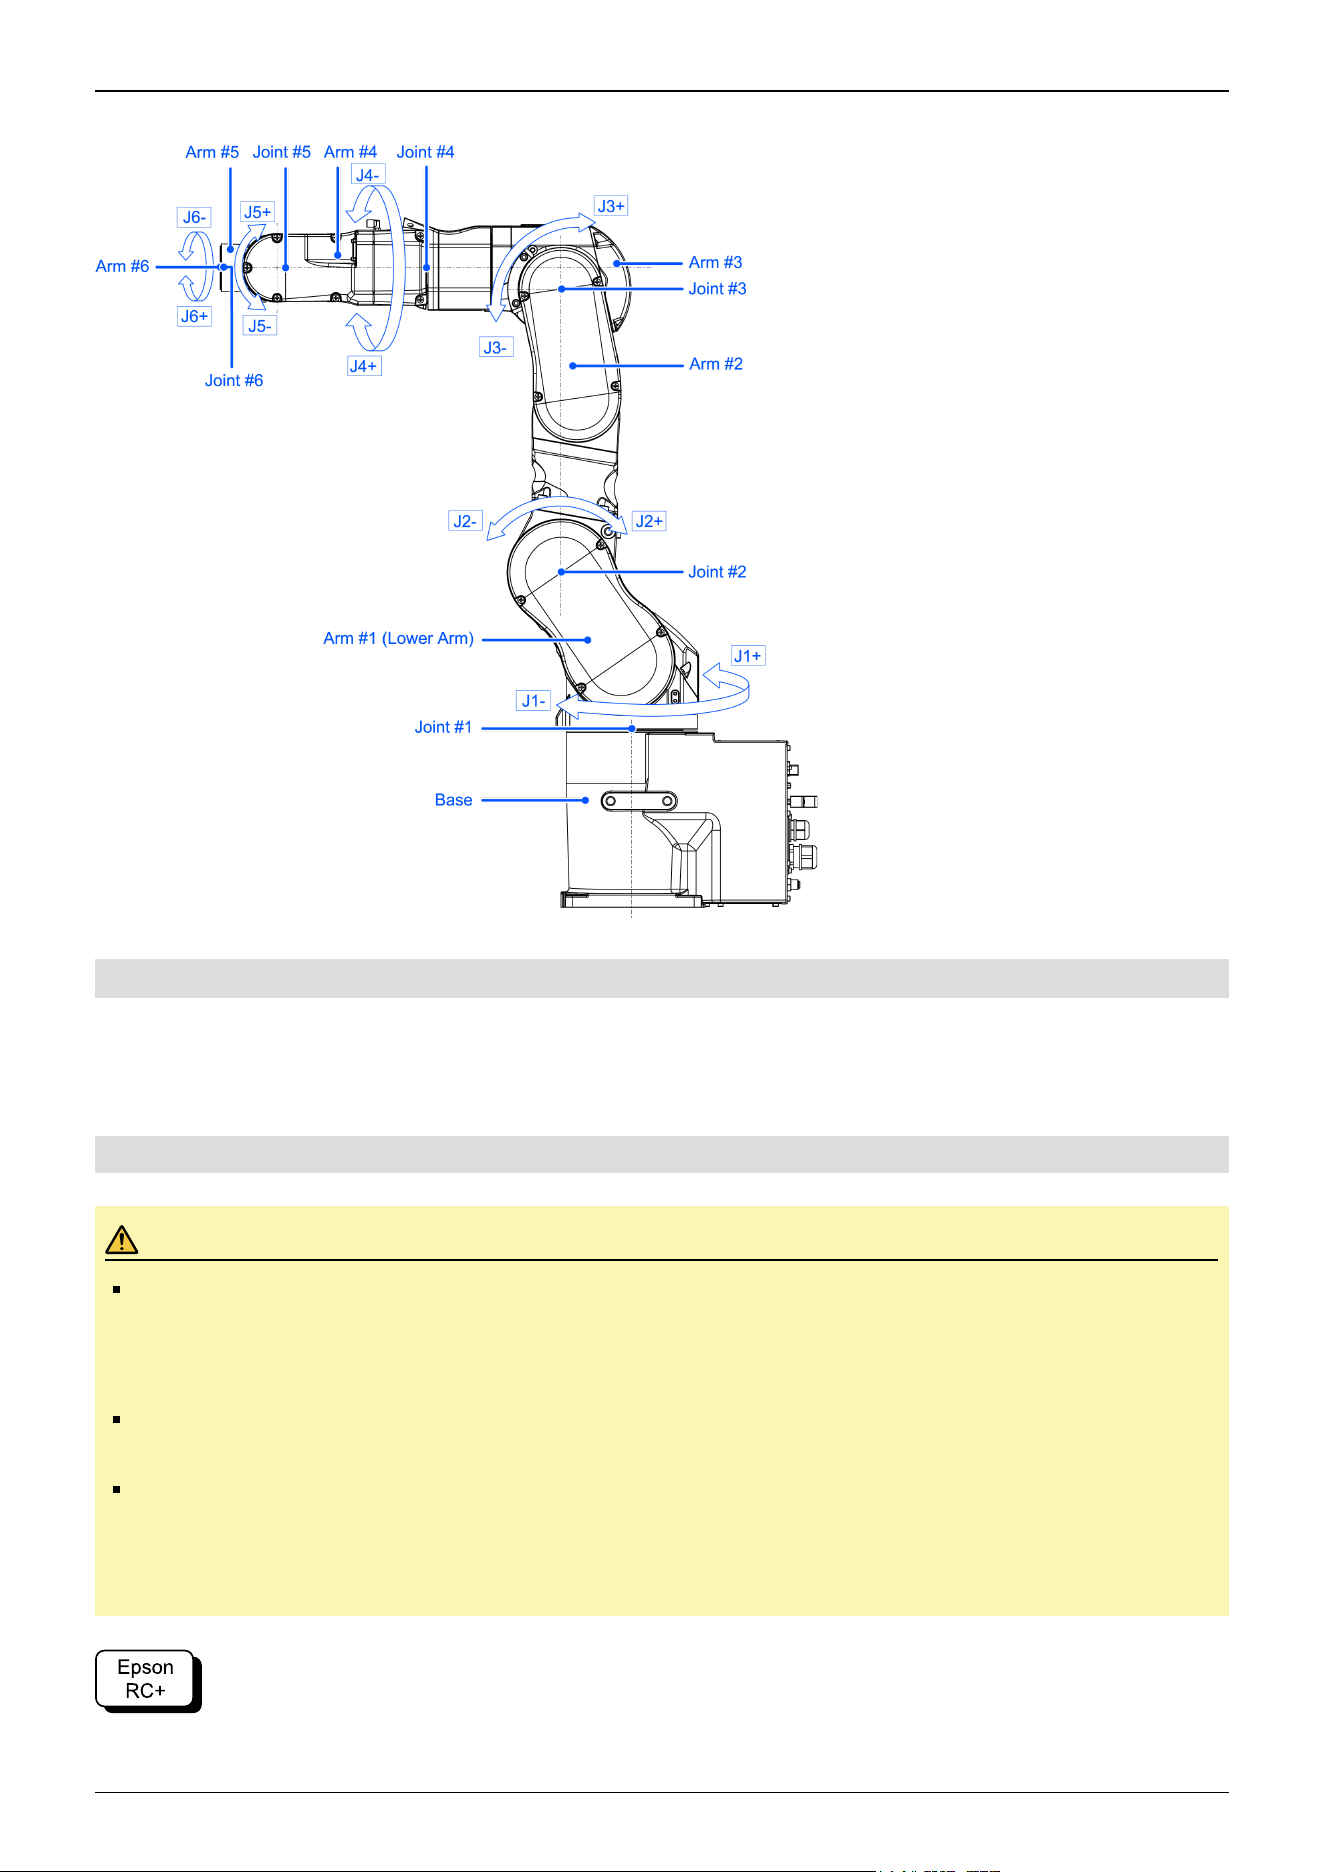
2.2.2 Part Names and Motion Range of Each Arm
Symbol Description
a Arm #1 (Lower Arm)
b Joint #1 (The whole Manipulator revolves.)
c Base
d Joint #2 (The lower arm swings.)
e Arm #2
f Joint #3 (The upper arm swings.)
g Arm #3
h LED Lamp (This lamp lights up while the motors are on.)
i Joint #4 (The wrist revolves.)
j Arm #4
k Joint #5 (The wrist swings.)
l Arm #5
m Arm #6
n Joint #6 (The hand rotates.)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
22
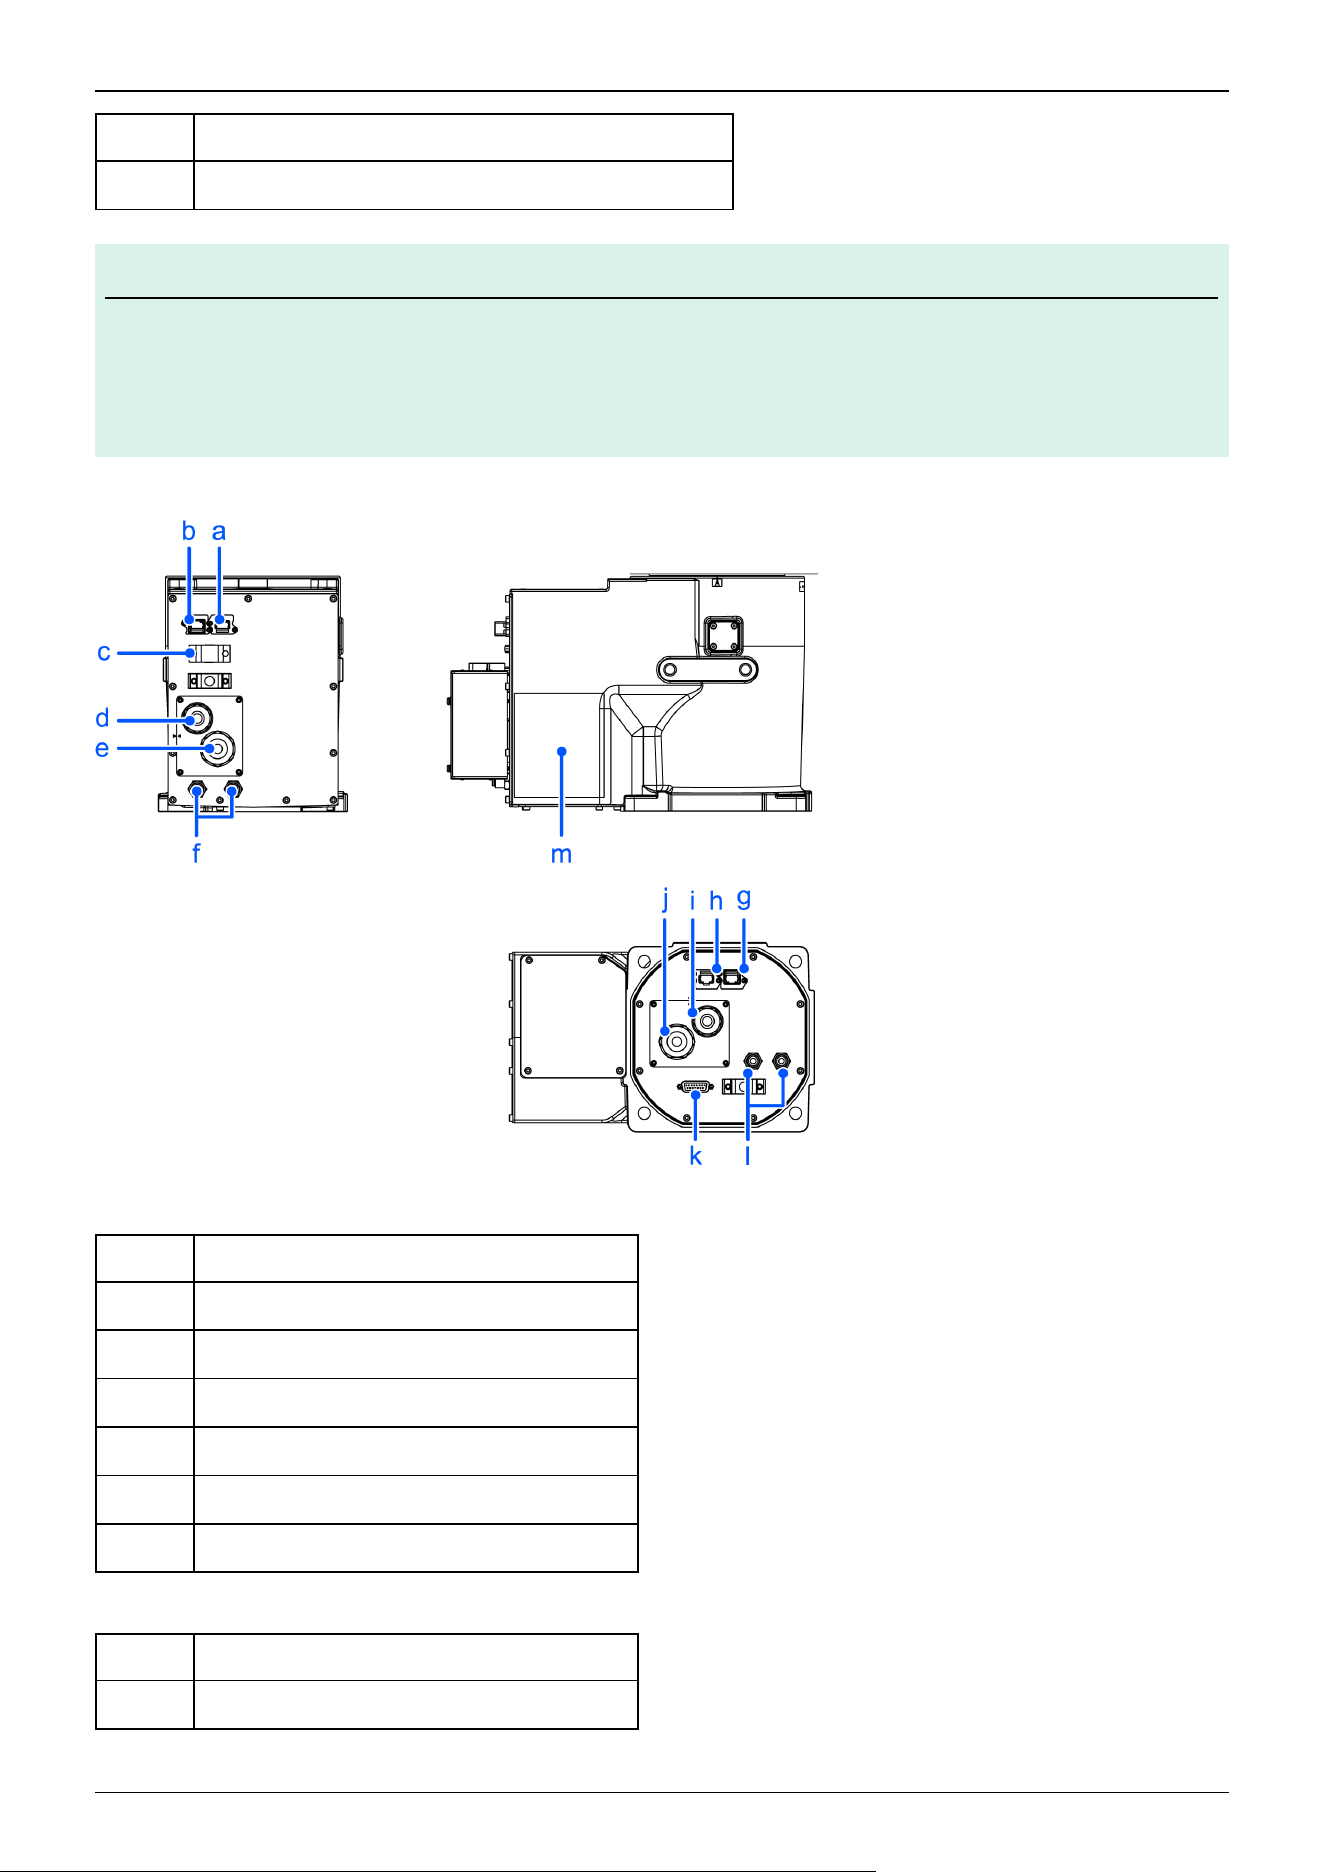
Symbol Description
o Upper Arm (Arms #3 to #6)
KEY POINTS
When the LED lamp is lighting or the Controller power is on, the current is being applied to the Manipulator. (The
LED lamp may not be seen depending on the Manipulator’s posture. Be thoroughly careful. Performing any work
procedure with the power turned on is extremely dangerous and may result in electric shock and/or malfunction
of the robot system. Before starting any maintenance work, be sure to turn off the Controller.
Cable backward model
Symbol Description
a Ethernet cable connector
b Force Sensor cable connector
c User cable connector (15-pin D-sub connector)
d Signal cable
e Power cable
f Fitting for ⌀6 mm tube (Air1, Air2)
Cable downward model
Symbol Description
g Force Sensor cable connector
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
23
Symbol Description
h Ethernet cable connector
i Signal cable
j Power cable
k User cable connector (15-pin D-sub connector)
l Fitting for ⌀6 mm tube (Air1, Air2)
Cable backward model, Cable downward model
Symbol Description
m Face plate (serial number of Manipulator)
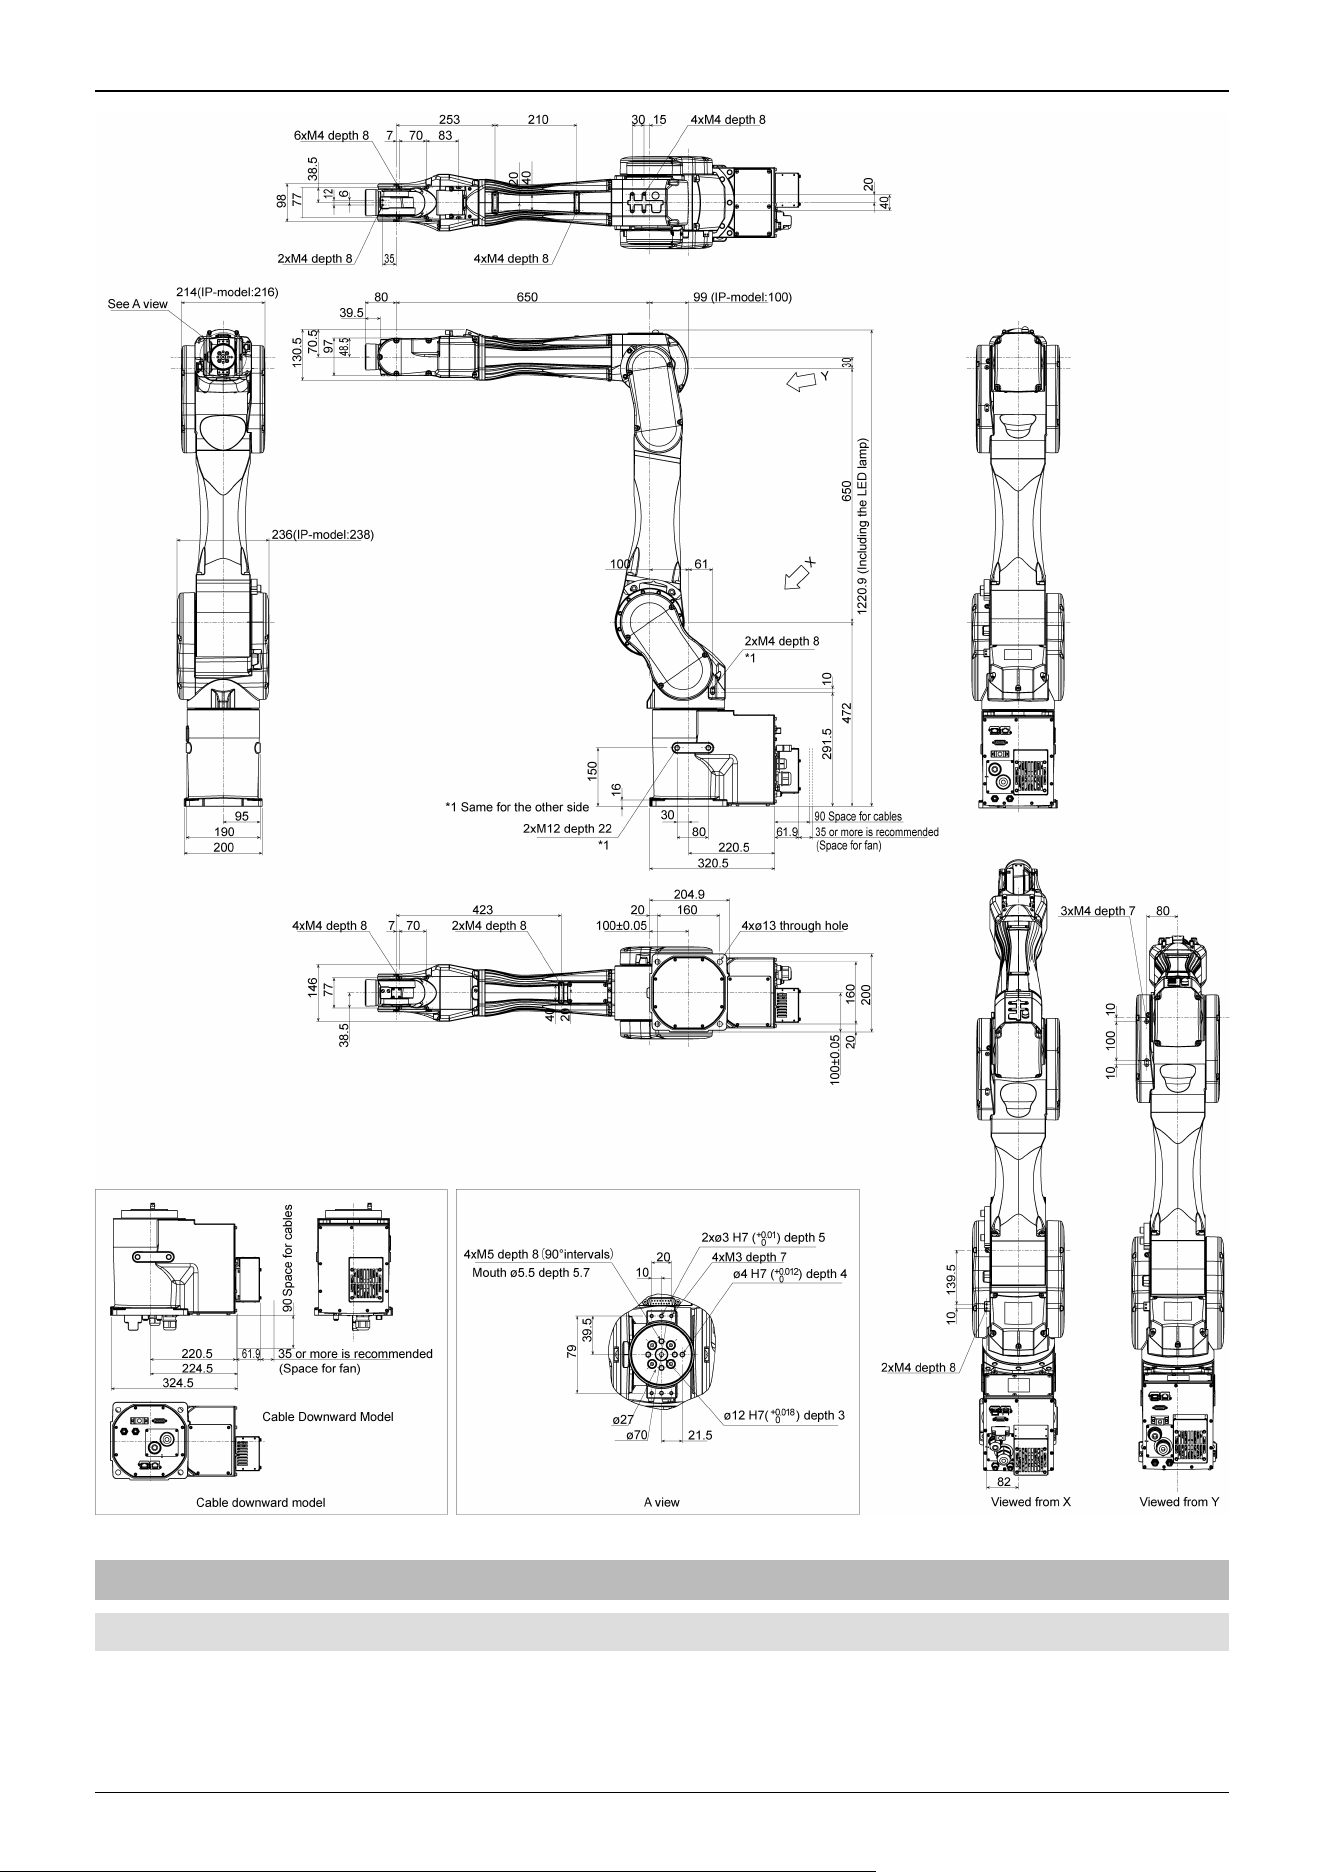
2.2.3 Outer Dimensions
2.2.3.1 C8-C901*** (C8L)
(Units: mm)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
24
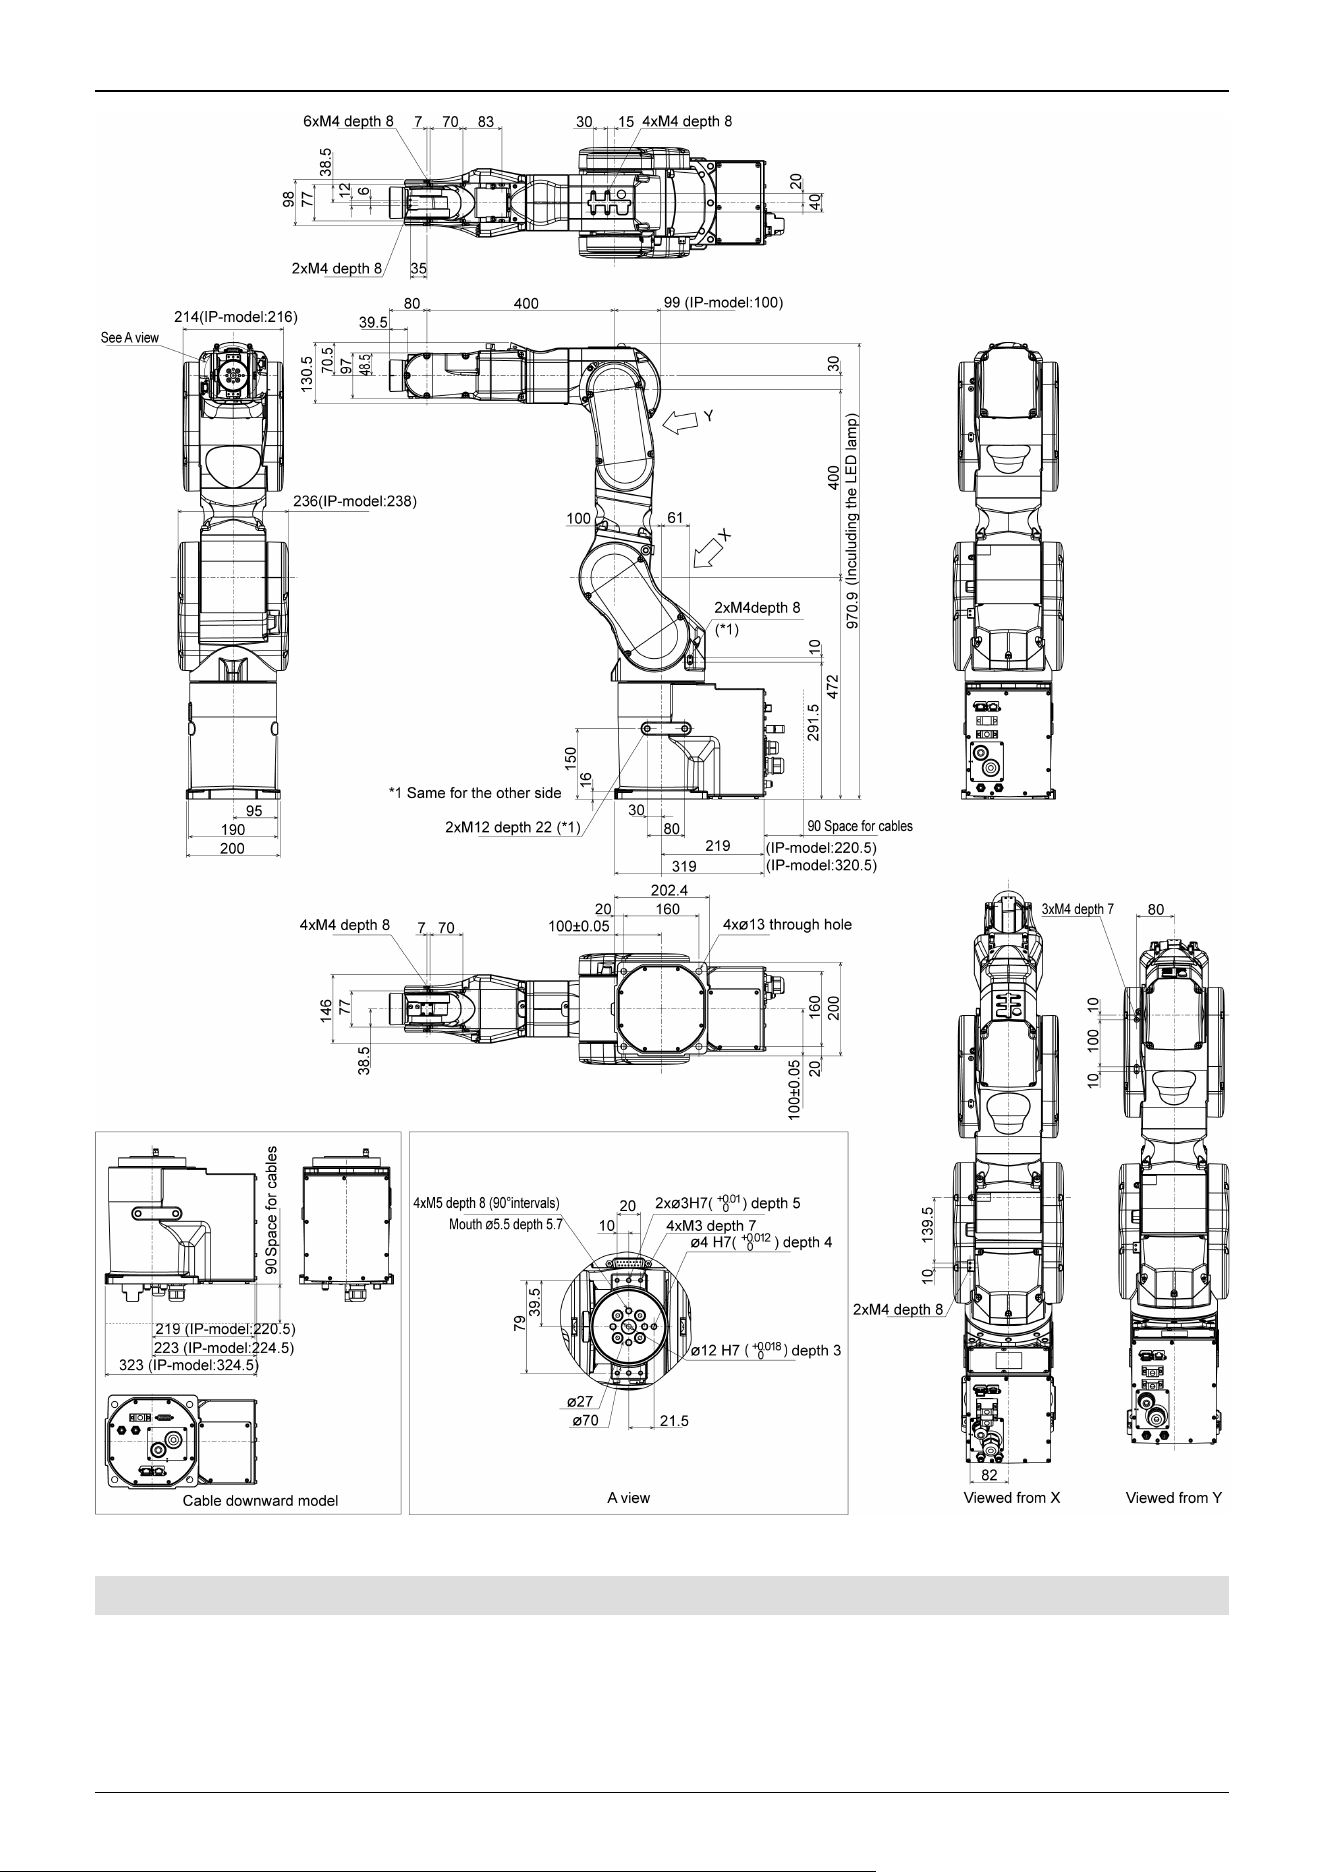
2.2.3.2 C8-C1401*** (C8L)
(Units: mm)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
25
2.2.4 Standard Work Envelope
2.2.4.1 C8-C901*** (C8L)
(Units: mm)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
26
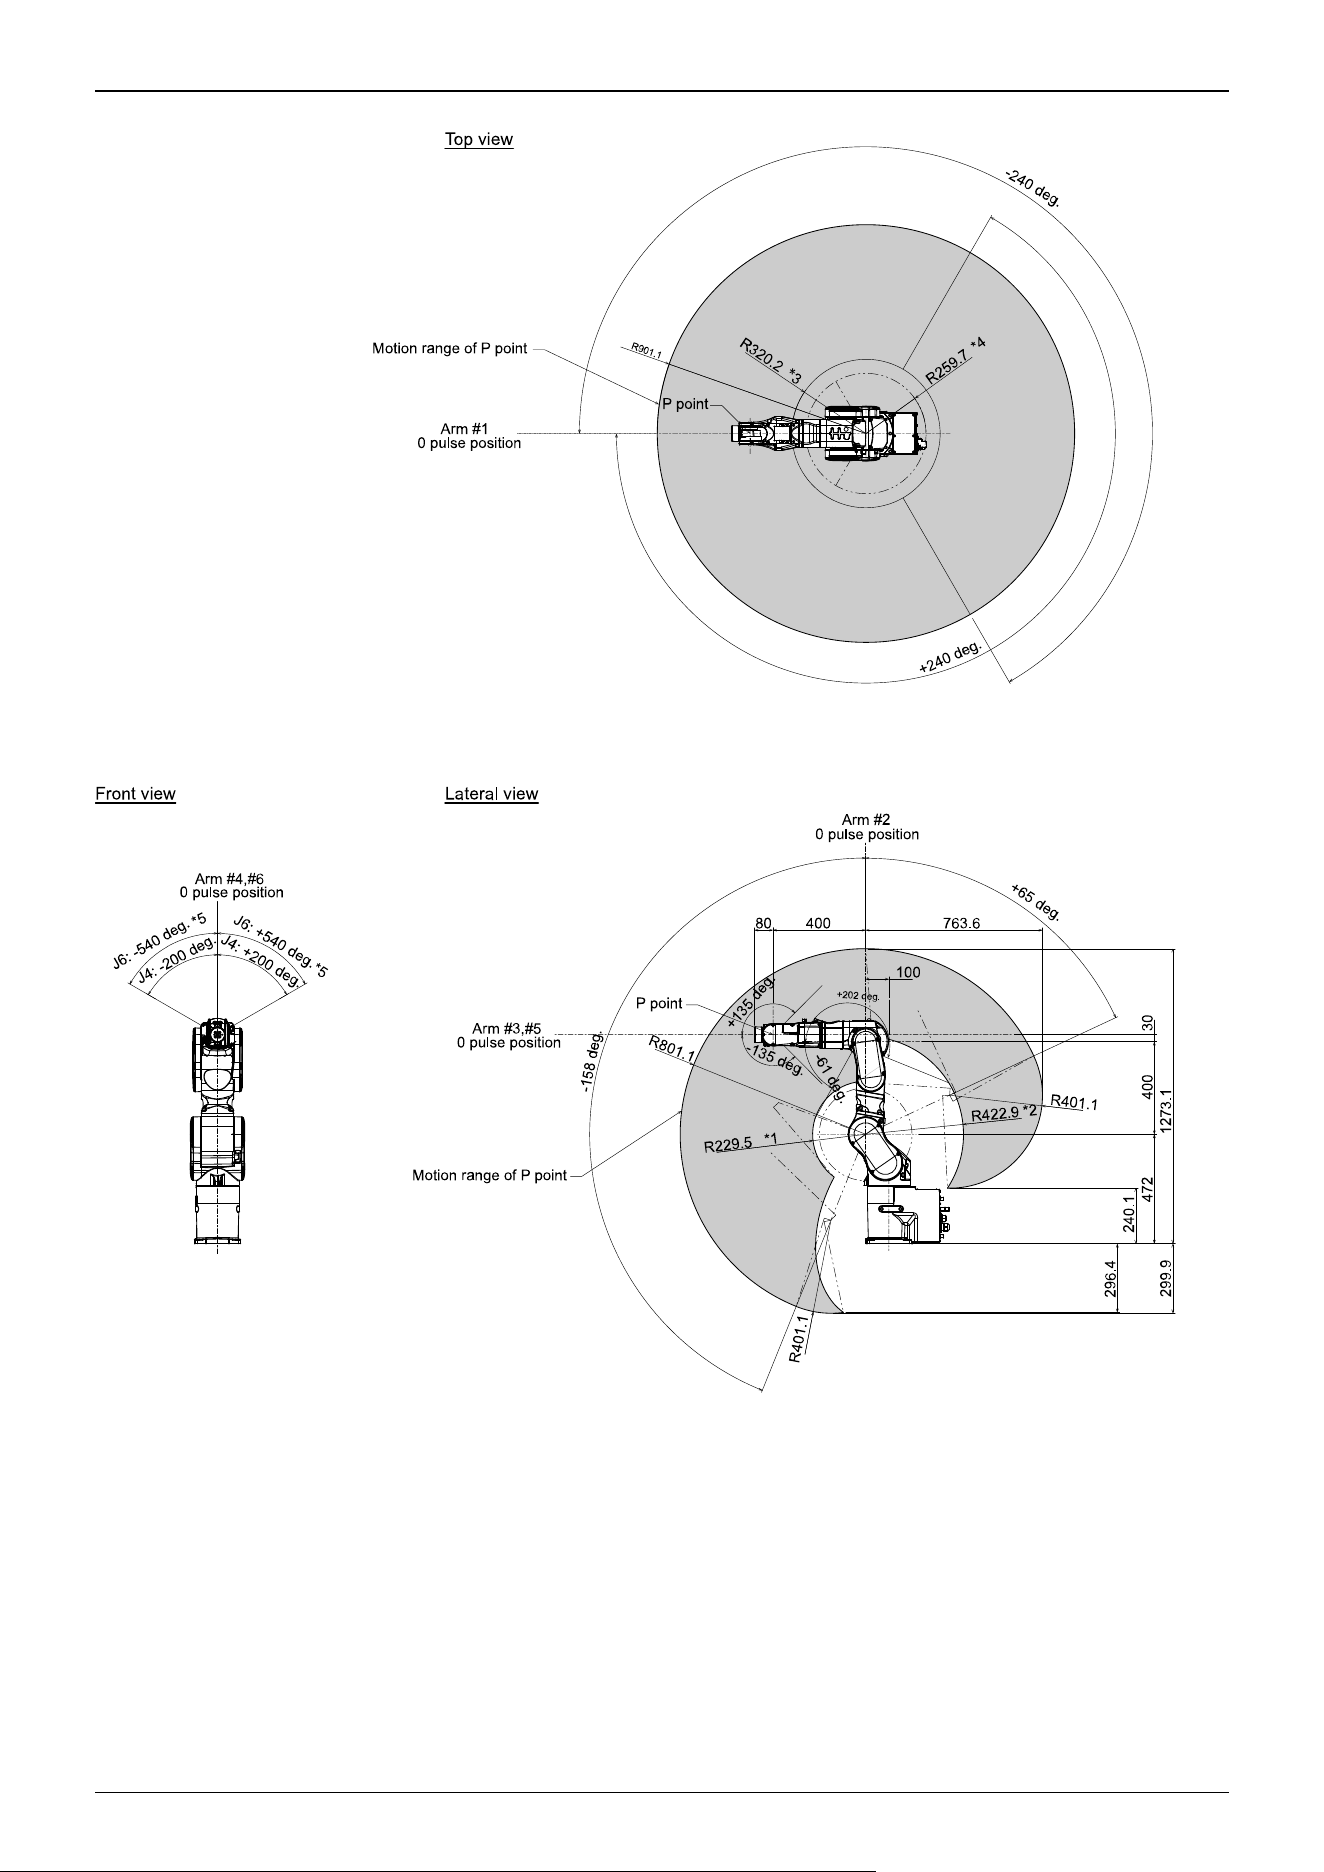
(deg. = °)
*P point: Intersection of the rotation centers for Joint #4, #5, and #6
*1: P point from lateral with Joint #3 declining -61° (Joint #2 center – P point center)
*2: P point from lateral with Joint #3 tilting up +202° (Joint #2 center – P point center)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
27
*3: P point from top with Joint #3 declining -61° (Joint #1 center – P point center)
*4: P point from top with Joint #3 tilting up +202° (Joint #1 center – P point center)
CAUTION
Pay attention to the arm pose of the basic arms (Arms #1, #2, and #3) when operating the Manipulator. Arm
#5 moves keeping a constant angle regardless of the arm pose. Depending on the arm pose of the basic
arms, the wrist may collide with the Manipulator. The collision may cause equipment damage to and/or
malfunction of the Manipulator.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
28
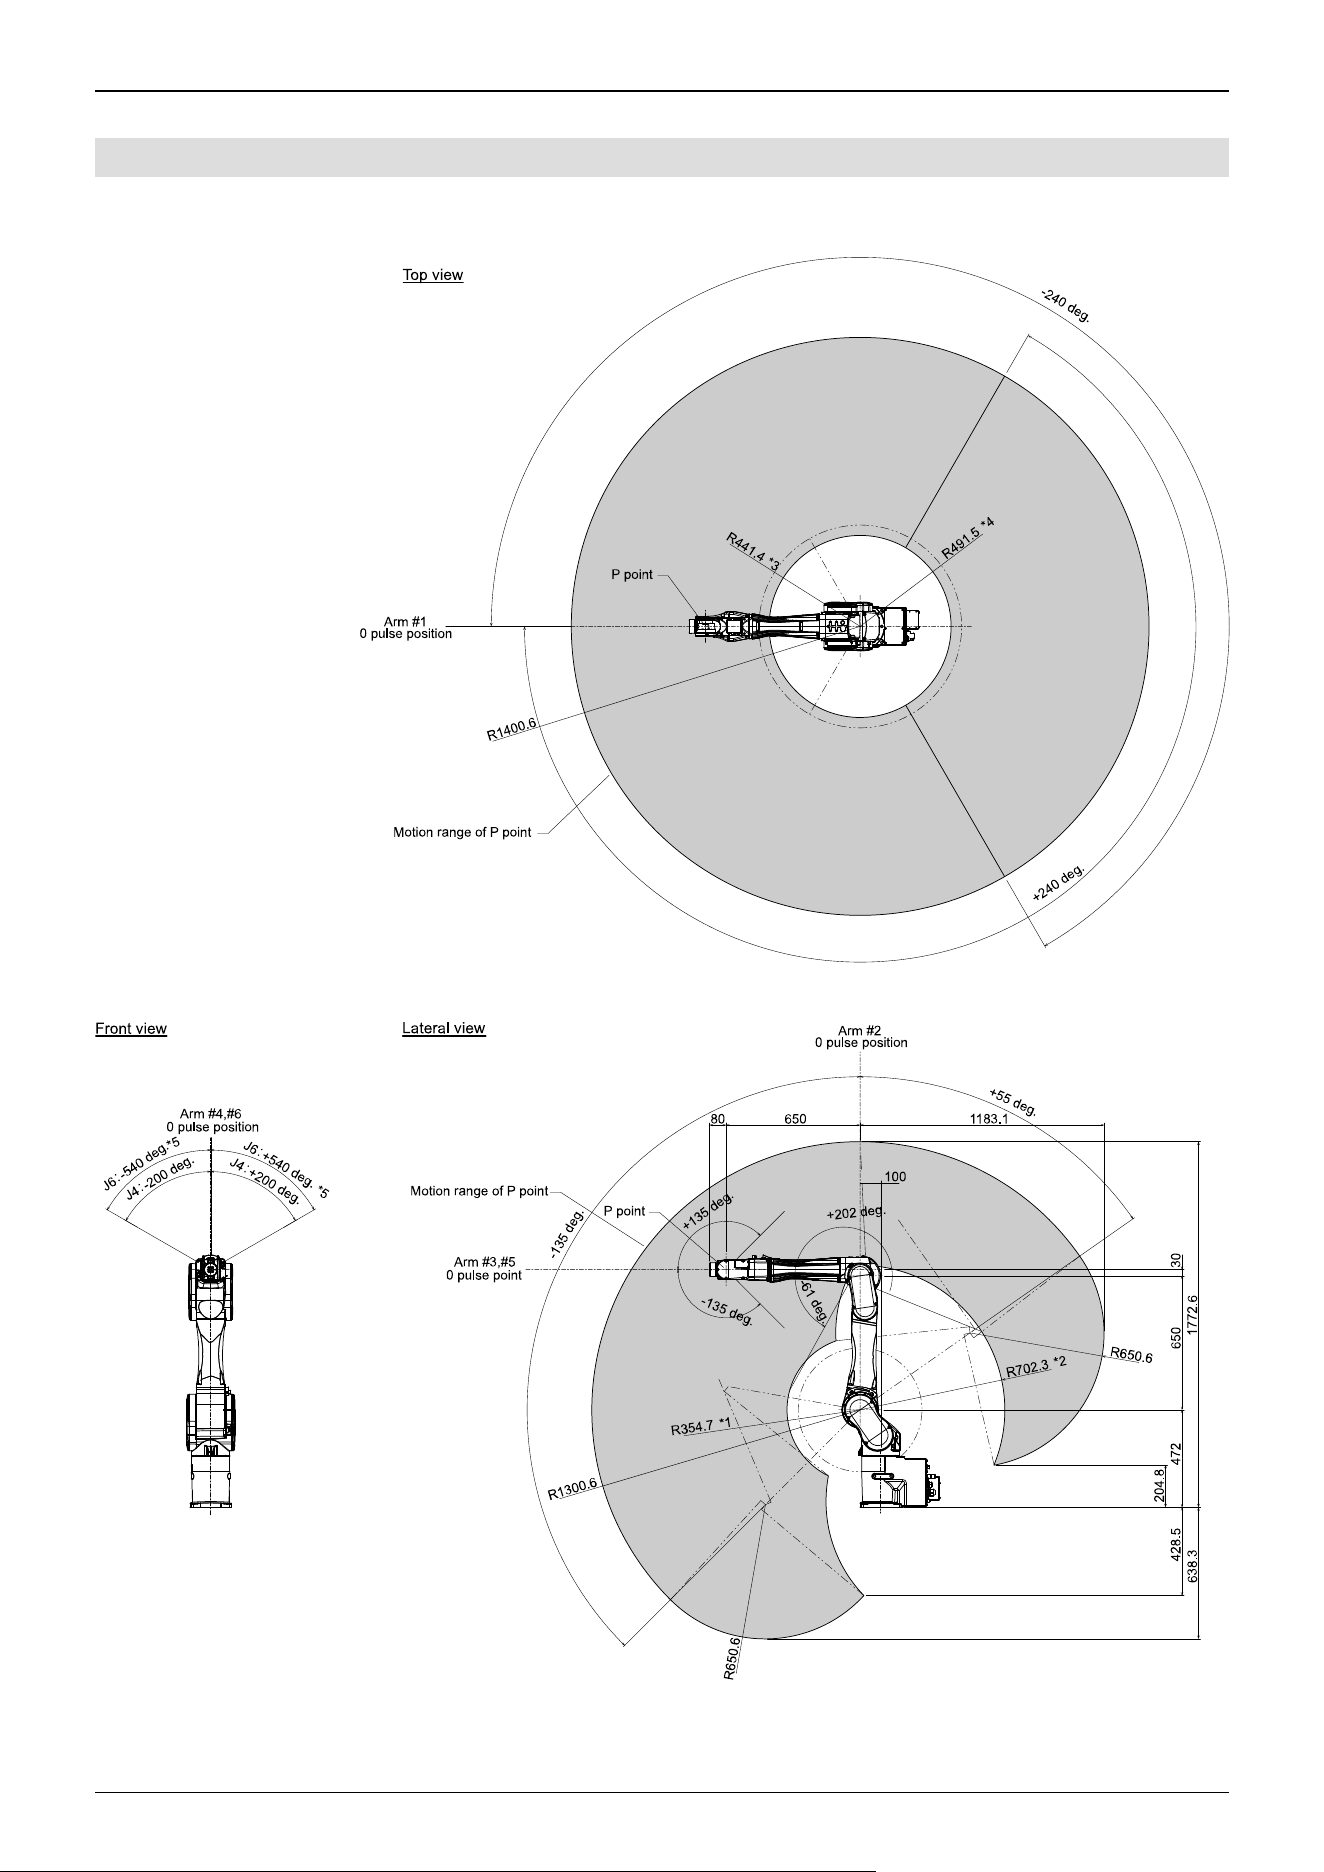
2.2.4.2 C8-C1401*** (C8XL)
(Units: mm)
(deg. = °)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
29
*P point: Intersection of the rotation centers for Joint #4, #5, and #6
*1: P point from lateral with Joint #3 declining -61° (Joint #2 center – P point center)
*2: P point from lateral with Joint #3 tilting up +202° (Joint #2 center – P point center)
*3: P point from top with Joint #3 declining -61° (Joint #1 center – P point center)
*4: P point from top with Joint #3 tilting up +202° (Joint #1 center – P point center)
*5: The motion range ±540° of J6 can be changed.For details, refer to the following.
Appendix
CAUTION
Pay attention to the arm pose of the basic arms (Arms #1, #2, and #3) when operating the Manipulator. Arm
#5 moves keeping a constant angle regardless of the arm pose. Depending on the arm pose of the basic
arms, the wrist may collide with the Manipulator. The collision may cause equipment damage to and/or
malfunction of the Manipulator.
2.2.5 Specifications
2.2.5.1 Specifications Table
For the specifications tables of each model, refer to the following section.
C8 Specifications
2.2.5.2 Options
For details, refer to the following section.
Options
2.2.6 How to Set the Model
The Manipulator model for your system has been set before shipment from the factory.
CAUTION
If changing the setting of the Manipulator model, be responsible and absolutely certain that the wrong
Manipulator model is not set. Incorrect setting of the Manipulator model may result in abnormal or no
operation by the Manipulator and could even cause safety problems.
If a custom specifications number (MT***) or (X***) is written on the face plate (serial number label), the Manipulator has
custom specifications.
Models with custom specifications may require a different setting procedure. Check the custom specifications number, and
contact the supplier for more information.
The Manipulator model is set from software. For details, refer to the following manual.
"Epson RC+ User's Guide - Robot Configuration"
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
30
2.3 Environment and Installation
The robot system should be designed and installed by people who have received installation training provided by Epson and
the suppliers. Also, the laws and regulations of the installation country must be followed.
2.3.1 Environment
To ensure that the robot system operates and maintains maximum performance and to ensure its safe use, the robot system
should be installed in an environment that meets the following requirements.
Item Conditions
Ambient temperature *
Installation: 5 to 40°C
Transport, storage: -20 to 60°C
Ambient relative humidity
Installation: 10 to 80% (no condensation)
Transport, storage: 10 to 90% (no condensation)
Fast transient burst noise 1 kV or less (signal line)
Electrostatic noise 4 kV or less
Altitude 1000 m or less
* The ambient temperature requirement is for the Manipulator only. For details on the environment requirements for the
connected Controller, refer to the Robot Controller manual.
KEY POINTS
When used in a low-temperature environment near the minimum temperature specified in the product
specifications, or when the unit is idle for a long period of time during holidays or at night, a collision detection
error or similar error may occur immediately after the start of operation due to high resistance in the drive unit. In
such cases, warm-up operation for about 10 minutes is recommended.
KEY POINTS
If there are conductive objects such as fences or ladders within 2.5 m of the Manipulator, these objects must be
grounded.
Also, depending on the environmental specifications of the Manipulator, the following requirements must be met.
Environmental Specifications Conditions
S, C, P
- Install indoors.
- Keep away from direct sunlight.
- Keep away from shocks or vibrations.
- Keep away from sources of electric noise.
- Keep away from explosive areas.
- Keep away from large quantities of radiation.
S, C
- Keep away from dust, oily smoke, salinity, metal powder, and other contaminants.
- Keep away from flammable or corrosive liquids and gases.
- Keep away from organic solvents, acids, alkalis, and chlorine cutting fluids.
- Keep away from water.
✏
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
31
The following items should also be taken into consideration for the installation environment of Manipulators with protected-
models.
These are compliant with the IP67 protection class (IEC 60529, JIS C0920). The Manipulators can be used in environments
where the possibility of dust, water, and water-soluble cutting oil falling of the Manipulator exists.
They can be installed in environments where dust, oil smoke, metal powder, and similar substances are airborne, but they
are not suitable for use with nitrile rubber oil seals, O-rings, packings, liquid gaskets, or other substances that impair
sealing performance.
The Manipulator cannot be used in environments exposed to liquids or airborne droplets that are corrosive such as acids or
alkalis.
In environments that are exposed to airborne droplets containing salt, rust may also form on the Manipulator.
Manipulator surfaces are generally oil-resistant, but if special oils are to be used, oil resistance should be checked before
use. For more information, please contact the supplier.
In environments with rapid changes in temperature and humidity, condensation may form inside the Manipulator.
When handling food directly, it is necessary to make sure that the Manipulator is not likely to contaminate the food. For
more information, please contact the supplier.
The Controllers used with Manipulators with protected-models do not have protection against harsh environments. The
Controller should be installed in a location that meets its operating environment requirements.
KEY POINTS
If the Manipulator will be used in a location that does not meet the above requirements, please contact the
supplier.
WARNING
Always use a circuit breaker for the Controller's power supply. Failure to use a circuit breaker may result in an
electrical shock hazard or malfunction due to an electrical leakage. Select the correct circuit breaker based on
the Controller that you are using. For details, refer to the following manual.
"Robot Controller Manual"
CAUTION
When cleaning the Manipulator, do not rub it strongly with alcohol or benzene. Coated surfaces may lose their
luster.
2.3.2 Manipulator Mounting Dimensions
Mounting Area
Also, besides the area required for installation of the Manipulator, Controller, peripheral equipment, and other devices, the
following space should be provided at a minimum.
Space for teaching
Space for maintenance and inspections (for installing jigs and working safely within the safety barriers)
Space for cables
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
32
KEY POINTS
When installing the cables, be sure to maintain sufficient distance from obstacles.
For the minimum bend radius of the M/C cable, refer to the following section.
C8 Specifications
Also, leave enough space for other cables so that they are not forced to bend at extreme angles.
KEY POINTS
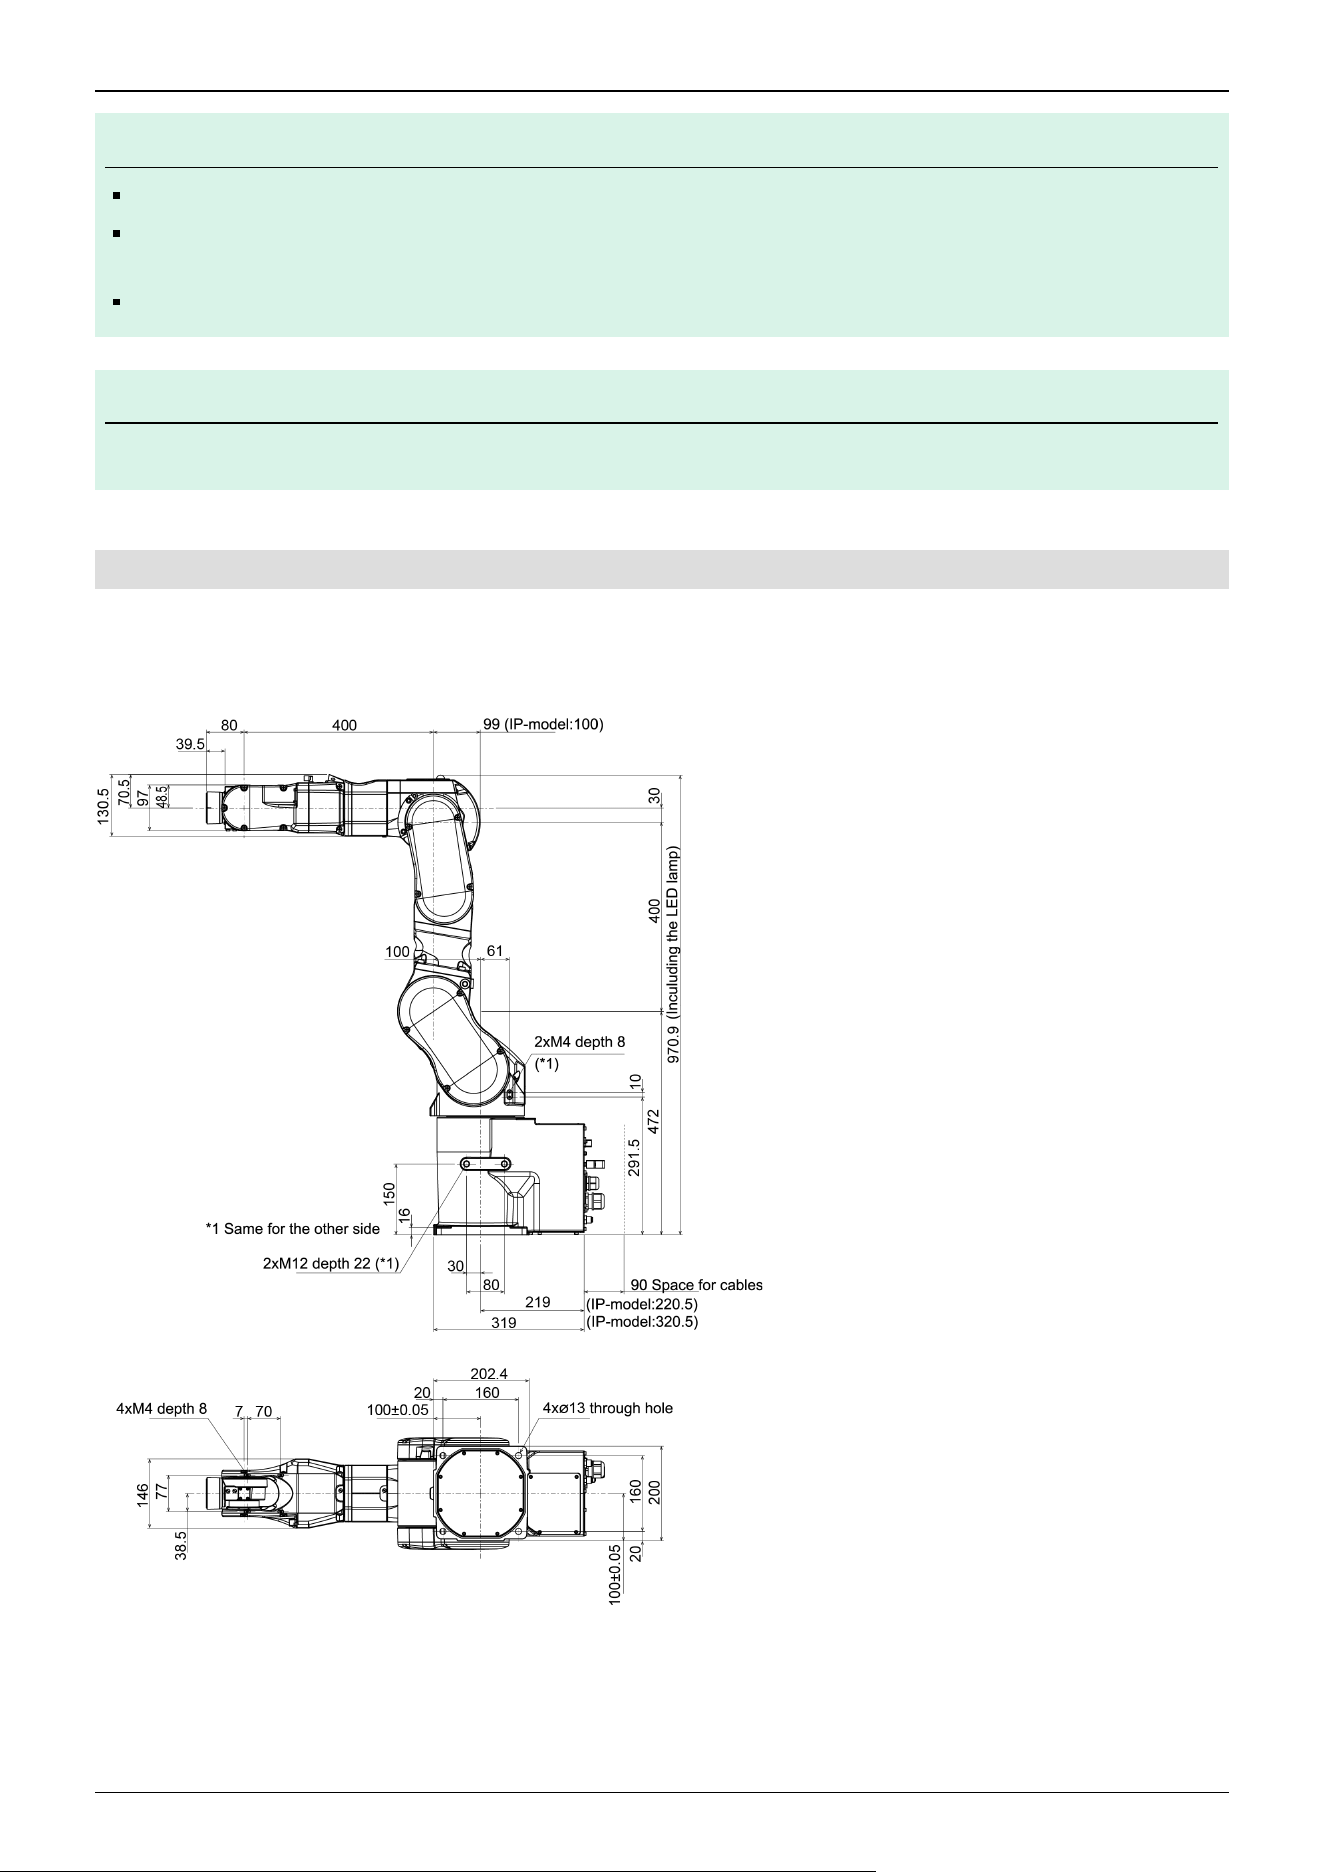
For C8-C1401*** (C8XL): Make sure to leave 35 mm or more space around the fan cover.
2.3.2.1 Cable backward model
(Units: mm)
C8-C901*** (C8L)
depth = depth of threaded hole
C8-C1401*** (C8XL)
✏
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
33
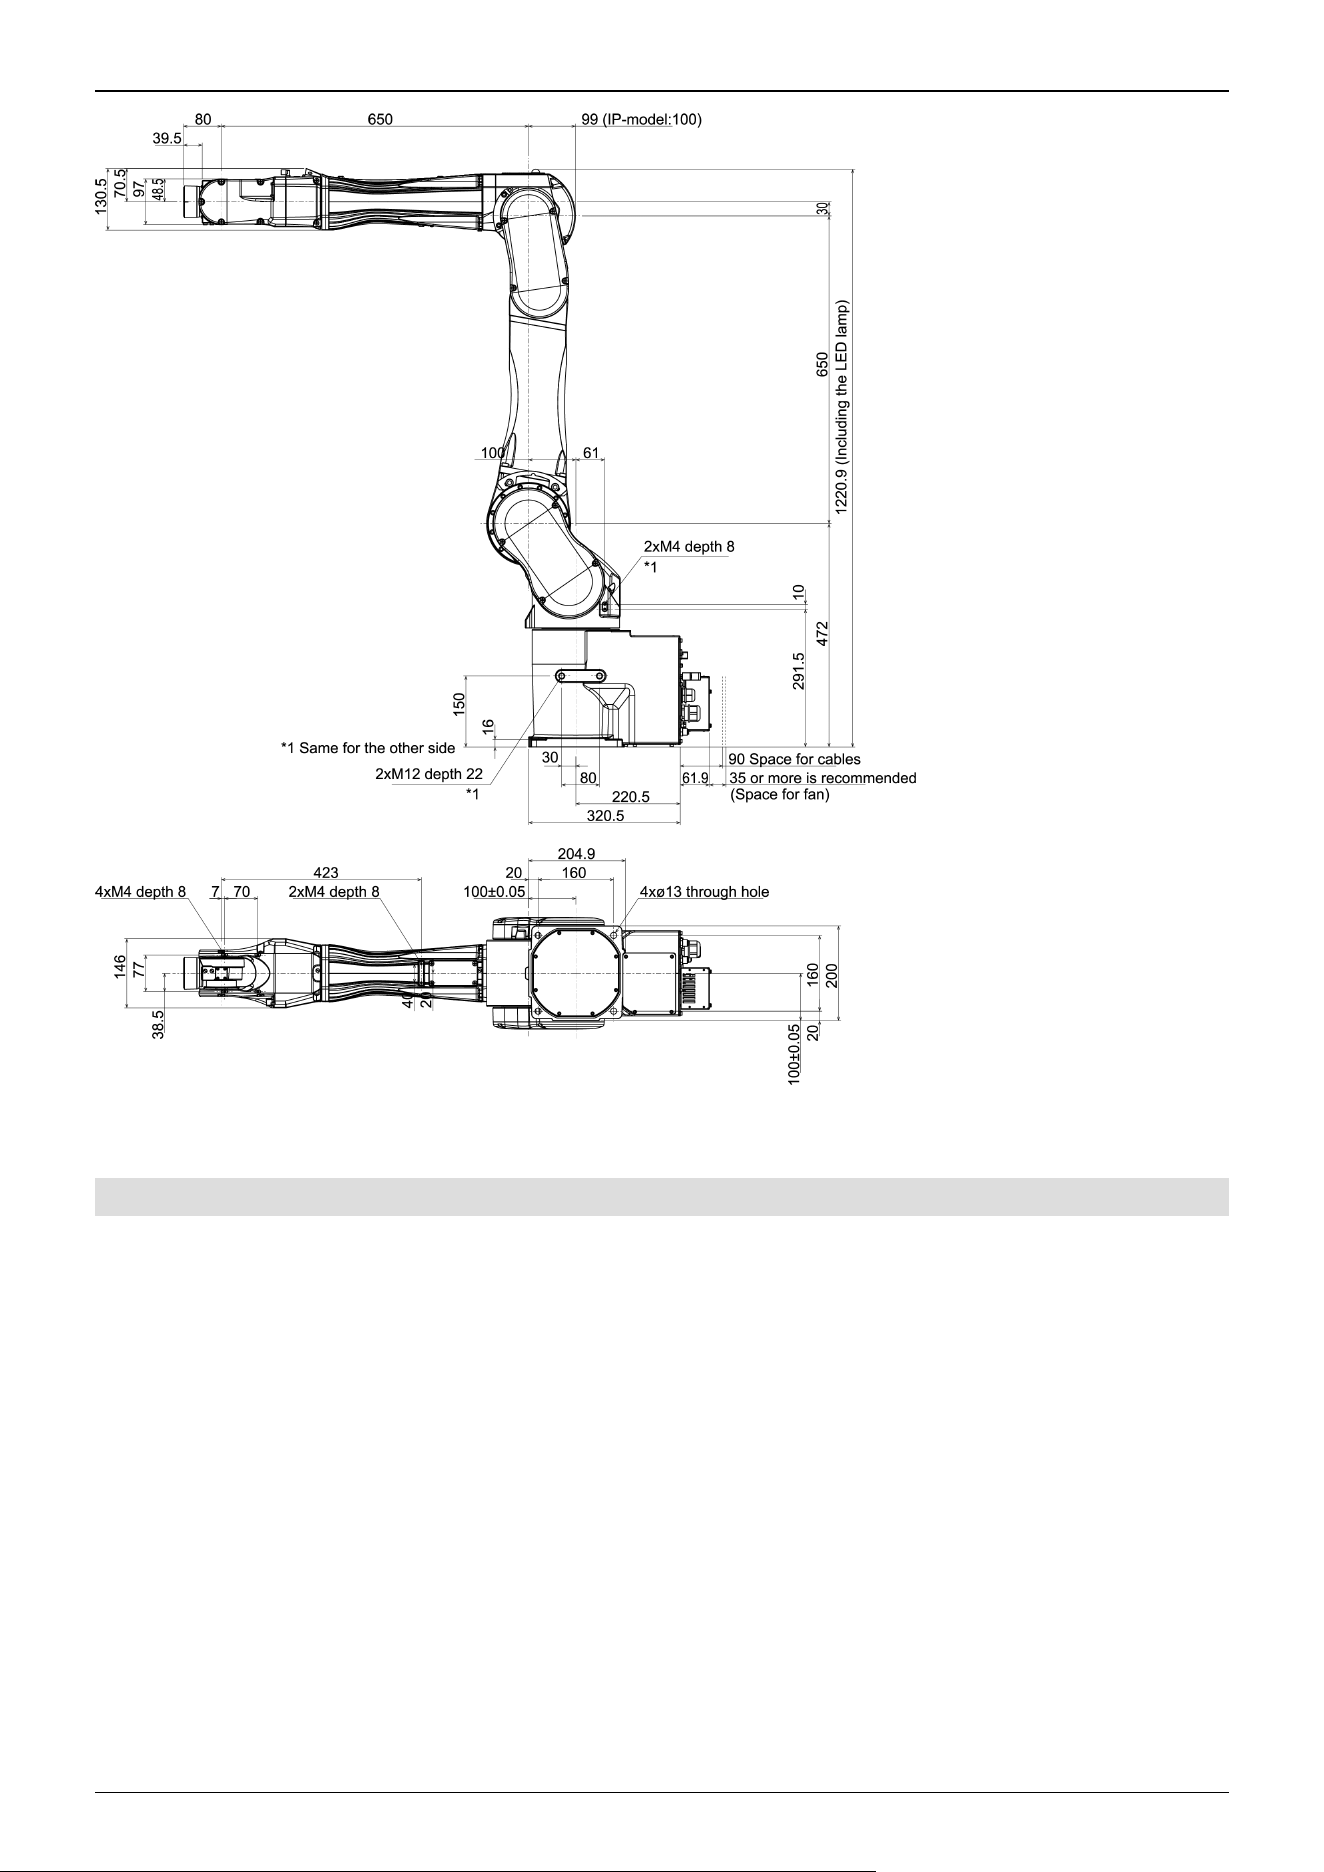
depth = depth of threaded hole
2.3.2.2 Cable downward model
The following part differs from the cable backward model.
C8-C901**B (C8L)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
34
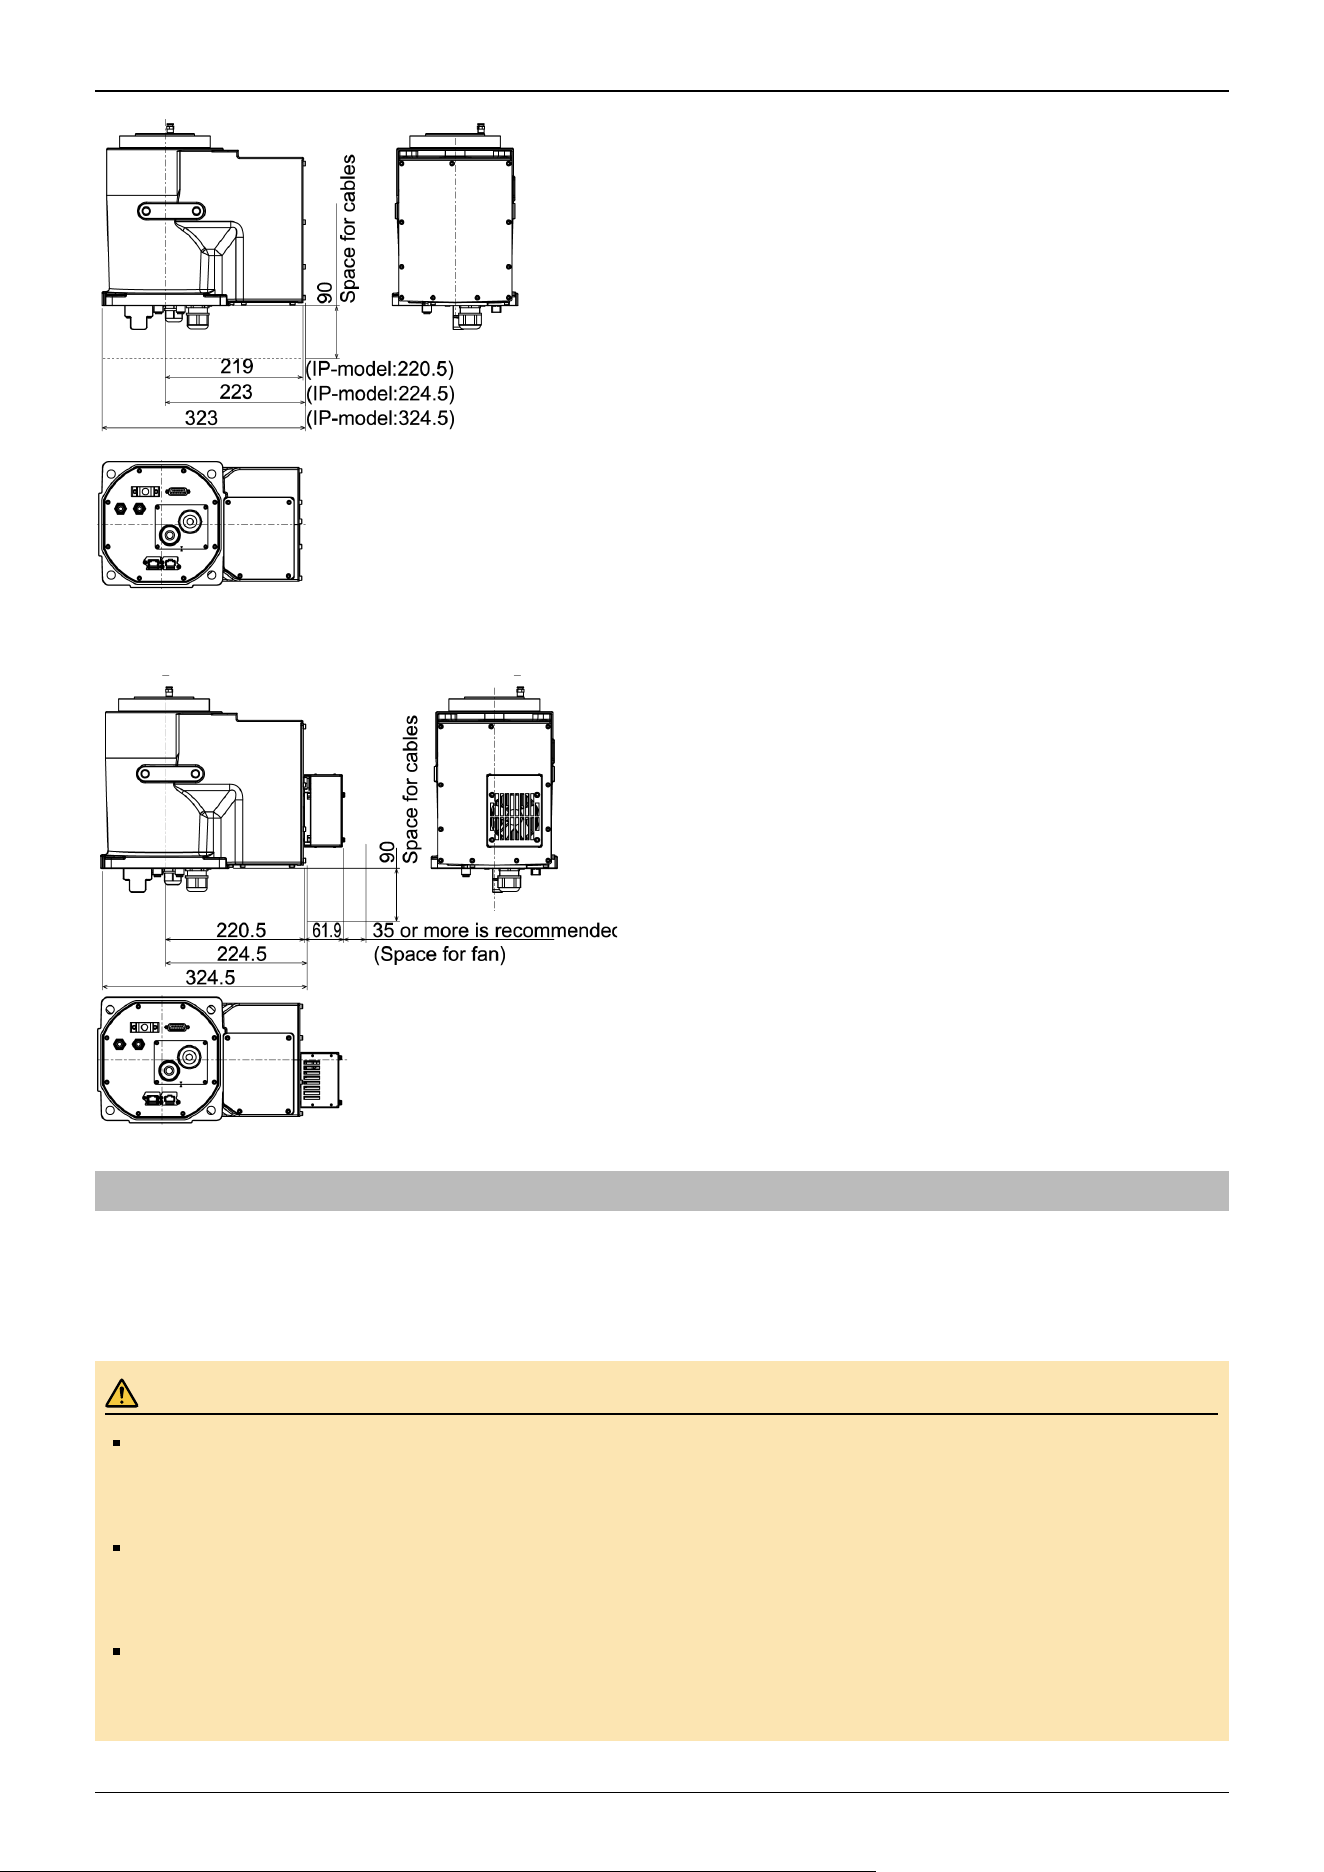
C8-C1401**B (C8XL)
2.3.3 From Unpacking to Installation
Transportation and installation of the Manipulator and related equipment should be performed by people who have received
installation training provided by Epson and the suppliers. Also, the laws and regulations of the installation country must be
followed.
WARNING
Only qualified personnel should perform sling work and operate a crane or a forklift. When these operations
are performed by unqualified personnel, it is extremely hazardous and may result in serious bodily injury
and/or severe equipment damage to the robot system
When hoisting the Manipulator, use your hands to balance it. Losing balance may cause the Manipulator to
drop, which is extremely hazardous and may result in serious injury and/or severe damage to the robot
system.
To ensure safety, be sure to install safeguards for the robot system. For more information on safeguards, refer
to the following manual.
"Epson RC+ User’s Guide - Safety - Installation and Design Precautions "
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
35
Install the Manipulator in a location with sufficient space so that a tool or a work piece does not touch a wall or
a safeguard when the Manipulator extends its arm fully while holding a work piece. If the tool or the workpiece
tip reaches a wall or safeguards, it is extremely hazardous and may result in serious bodily injury and/or
severe equipment damage to the robot system.
Be sure to anchor the Manipulator before turning on the power or operating it. Turning on the power or
operating the Manipulator while it is not anchored may cause the Manipulator to fall over, which is extremely
hazardous and may result in serious injury and/or severe damage to the robot system.
Before installing or operating the Manipulator, make sure that no parts of the Manipulator are missing and that
it has no damage or other external defects. Missing parts or damage may cause malfunction of the
Manipulator, is extremely hazardous, and may result in serious injury and/or severe equipment damage to the
robot system.
CAUTION
Use a cart or the like to transport the Manipulator in the same status as it was delivered.
When removing the fixing bolts securing the Manipulator to the transportation pallet and the packing box or
the anchor bolts, support the Manipulator to prevent it falling. Removing the fixing bolts or anchor bolts
without supporting the Manipulator may cause it to fall, catching your hands or feet.
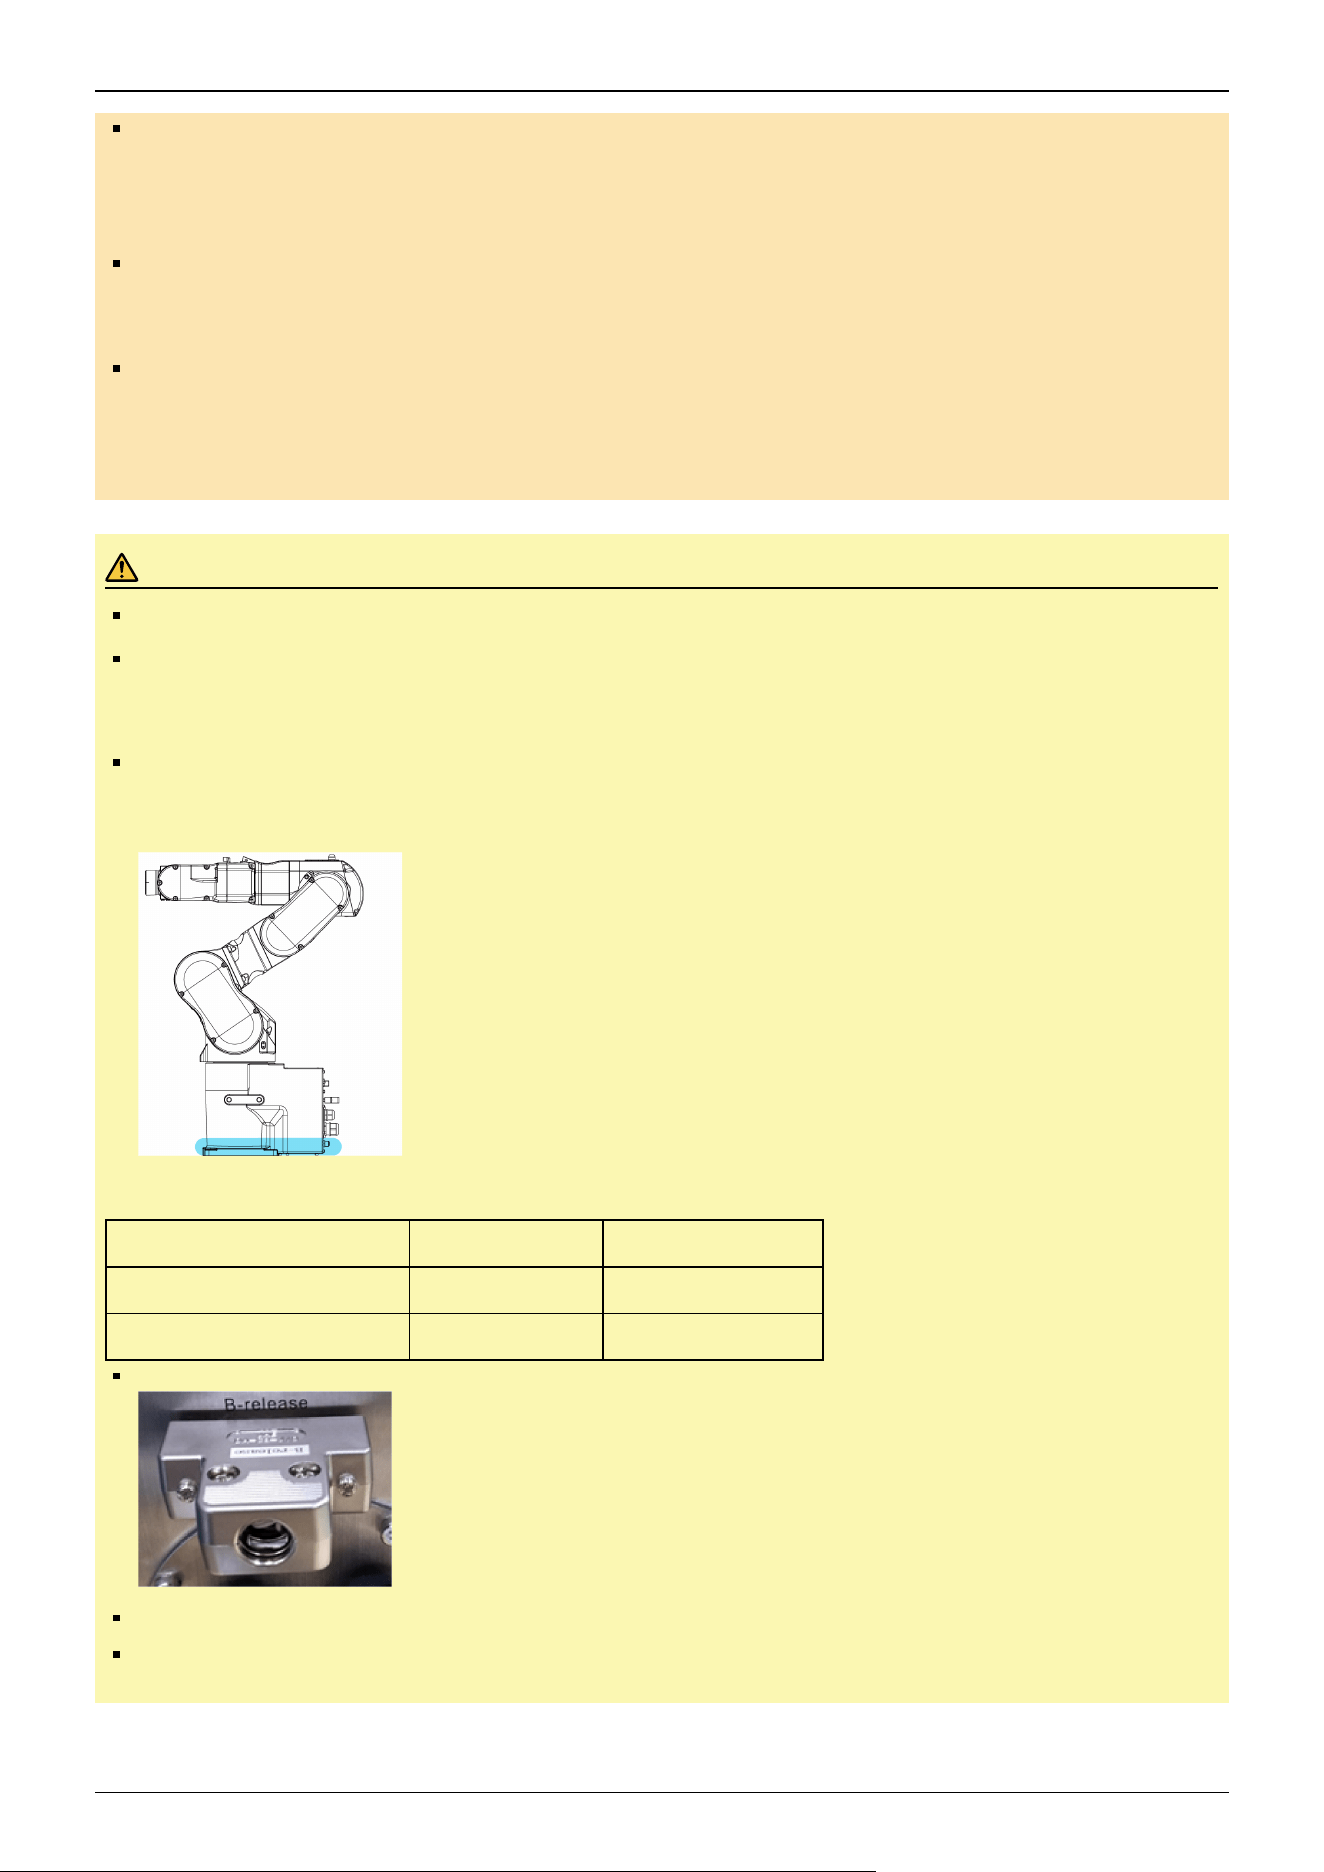
The Manipulator should be transported by two or more people or secured to transporting equipment. Also, do
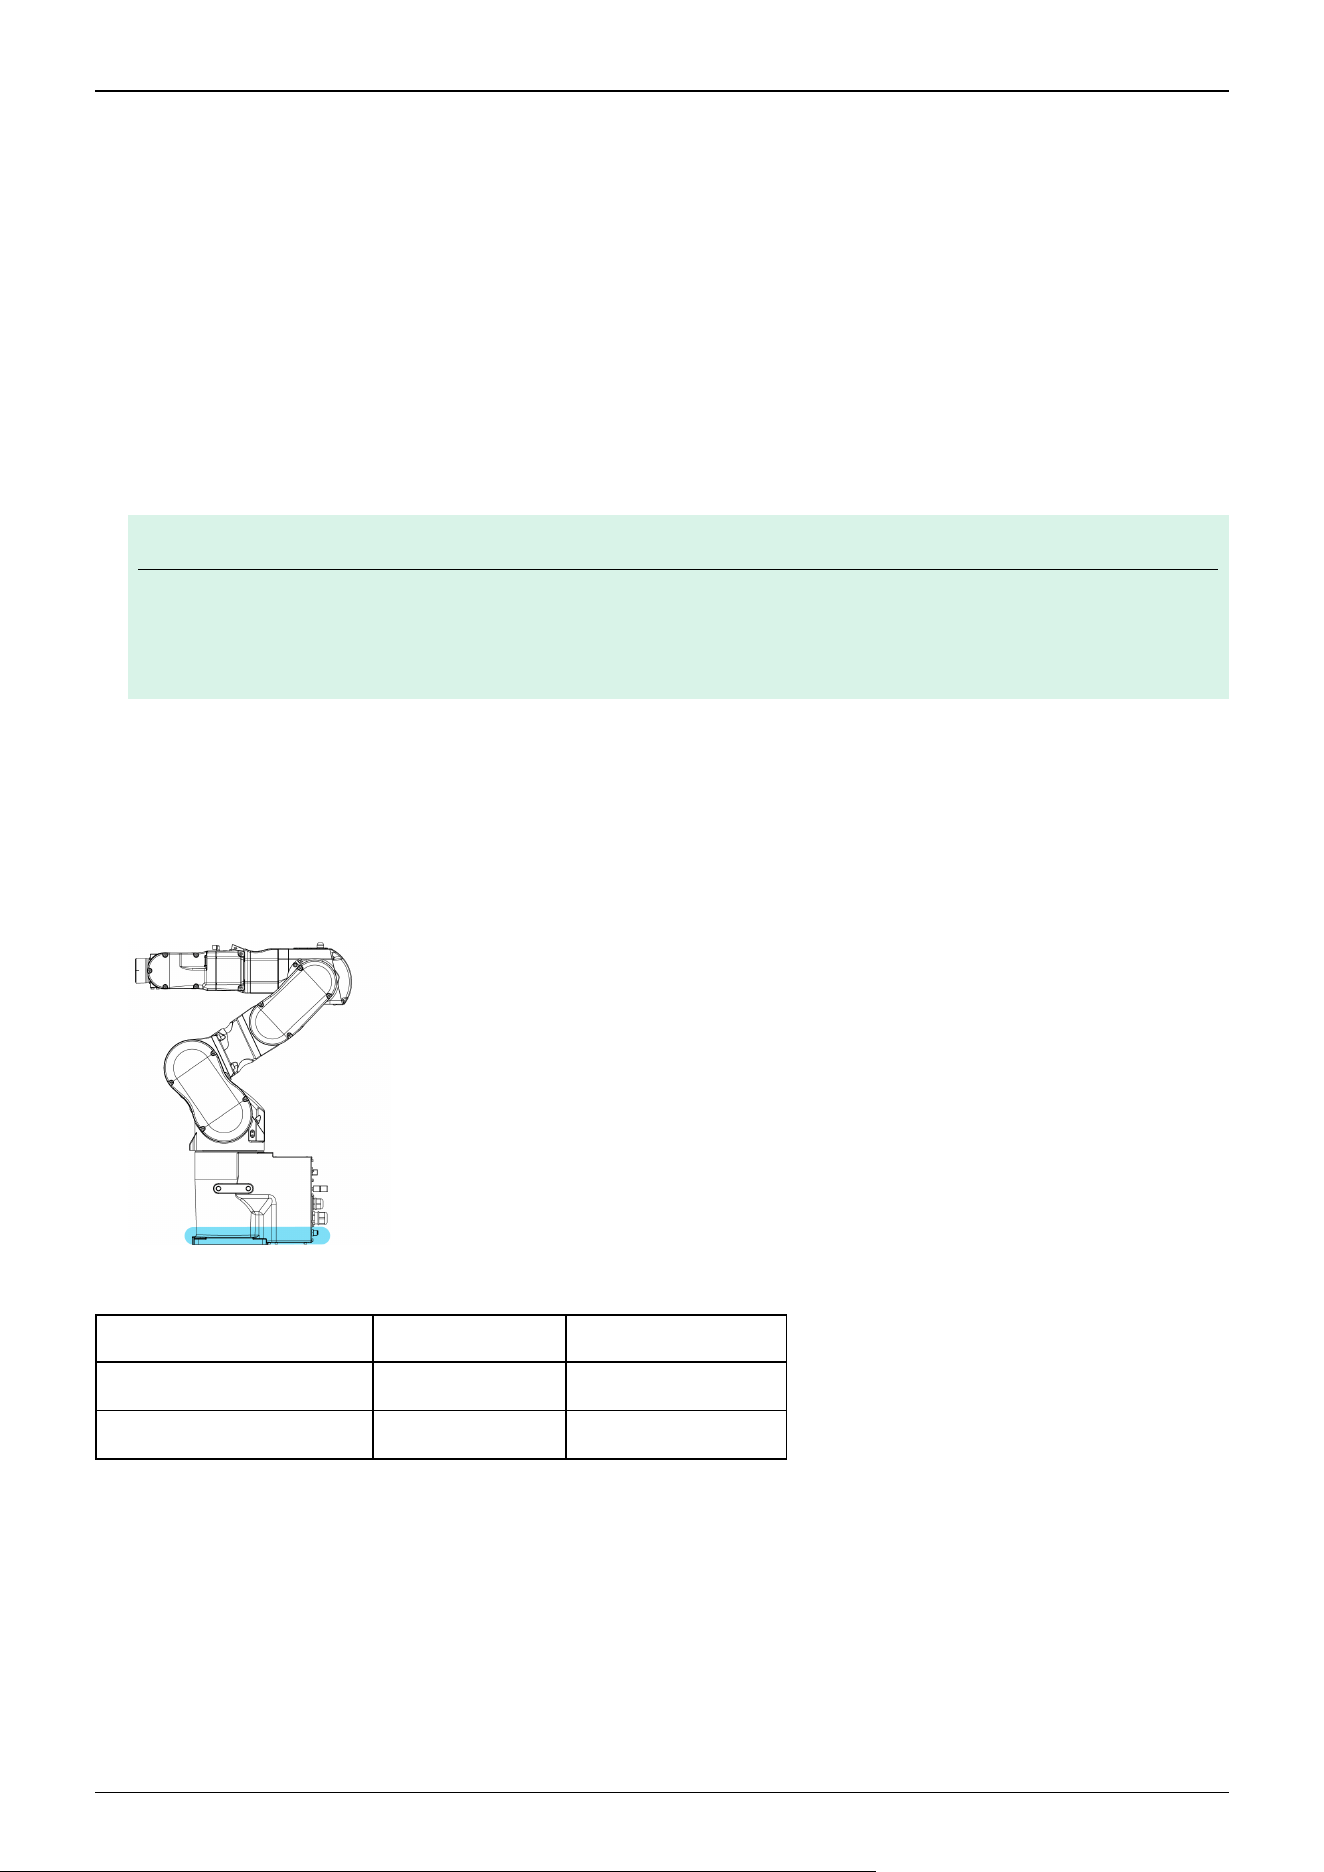
not hold the bottom of the base (the screened parts in the figure). Holding these parts by hand is extremely
hazardous and may cause your hands and fingers caught.
Manipulator weight
C8-C901***: C8L C8-C1401***: C8XL
Standard, Cleanroom Model 53 kg: 117 lb 63 kg: 139 lb
Protected-Model 57 kg: 126 lb 66 kg: 146 lb
Take extra care when transporting the Manipulator. You may hit and damage the connector.
During unpacking and relocation, avoid applying external force to the arms and motors of the Manipulator.
When transporting the Manipulator over long distances, secure it directly to transporting equipment so that it
will not fall. If necessary, pack the Manipulator using the same packaging as delivery.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
36
The Manipulator must be installed to avoid interference with surrounding buildings, structures, and other
machines and equipment that may create a trapping hazard or pinch points.
Resonance (resonating sound or minute vibrations) may occur during Manipulator operation depending on
the rigidity of the base table. If the resonance occurs, improve the rigidity of the base table or change the
speed or acceleration and deceleration settings of the Manipulator.
C8-C1401** has a cooling fan on the base. Install the Manipulator not to seal the cooling fan. For details, refer
to the following figure.
Cable backward model
Cable downward model
Protective tape
Remove the protective tape (4 places).
Fixing bolt
For details on the dimensions, refer to the following sections.
Manipulator Mounting Dimensions
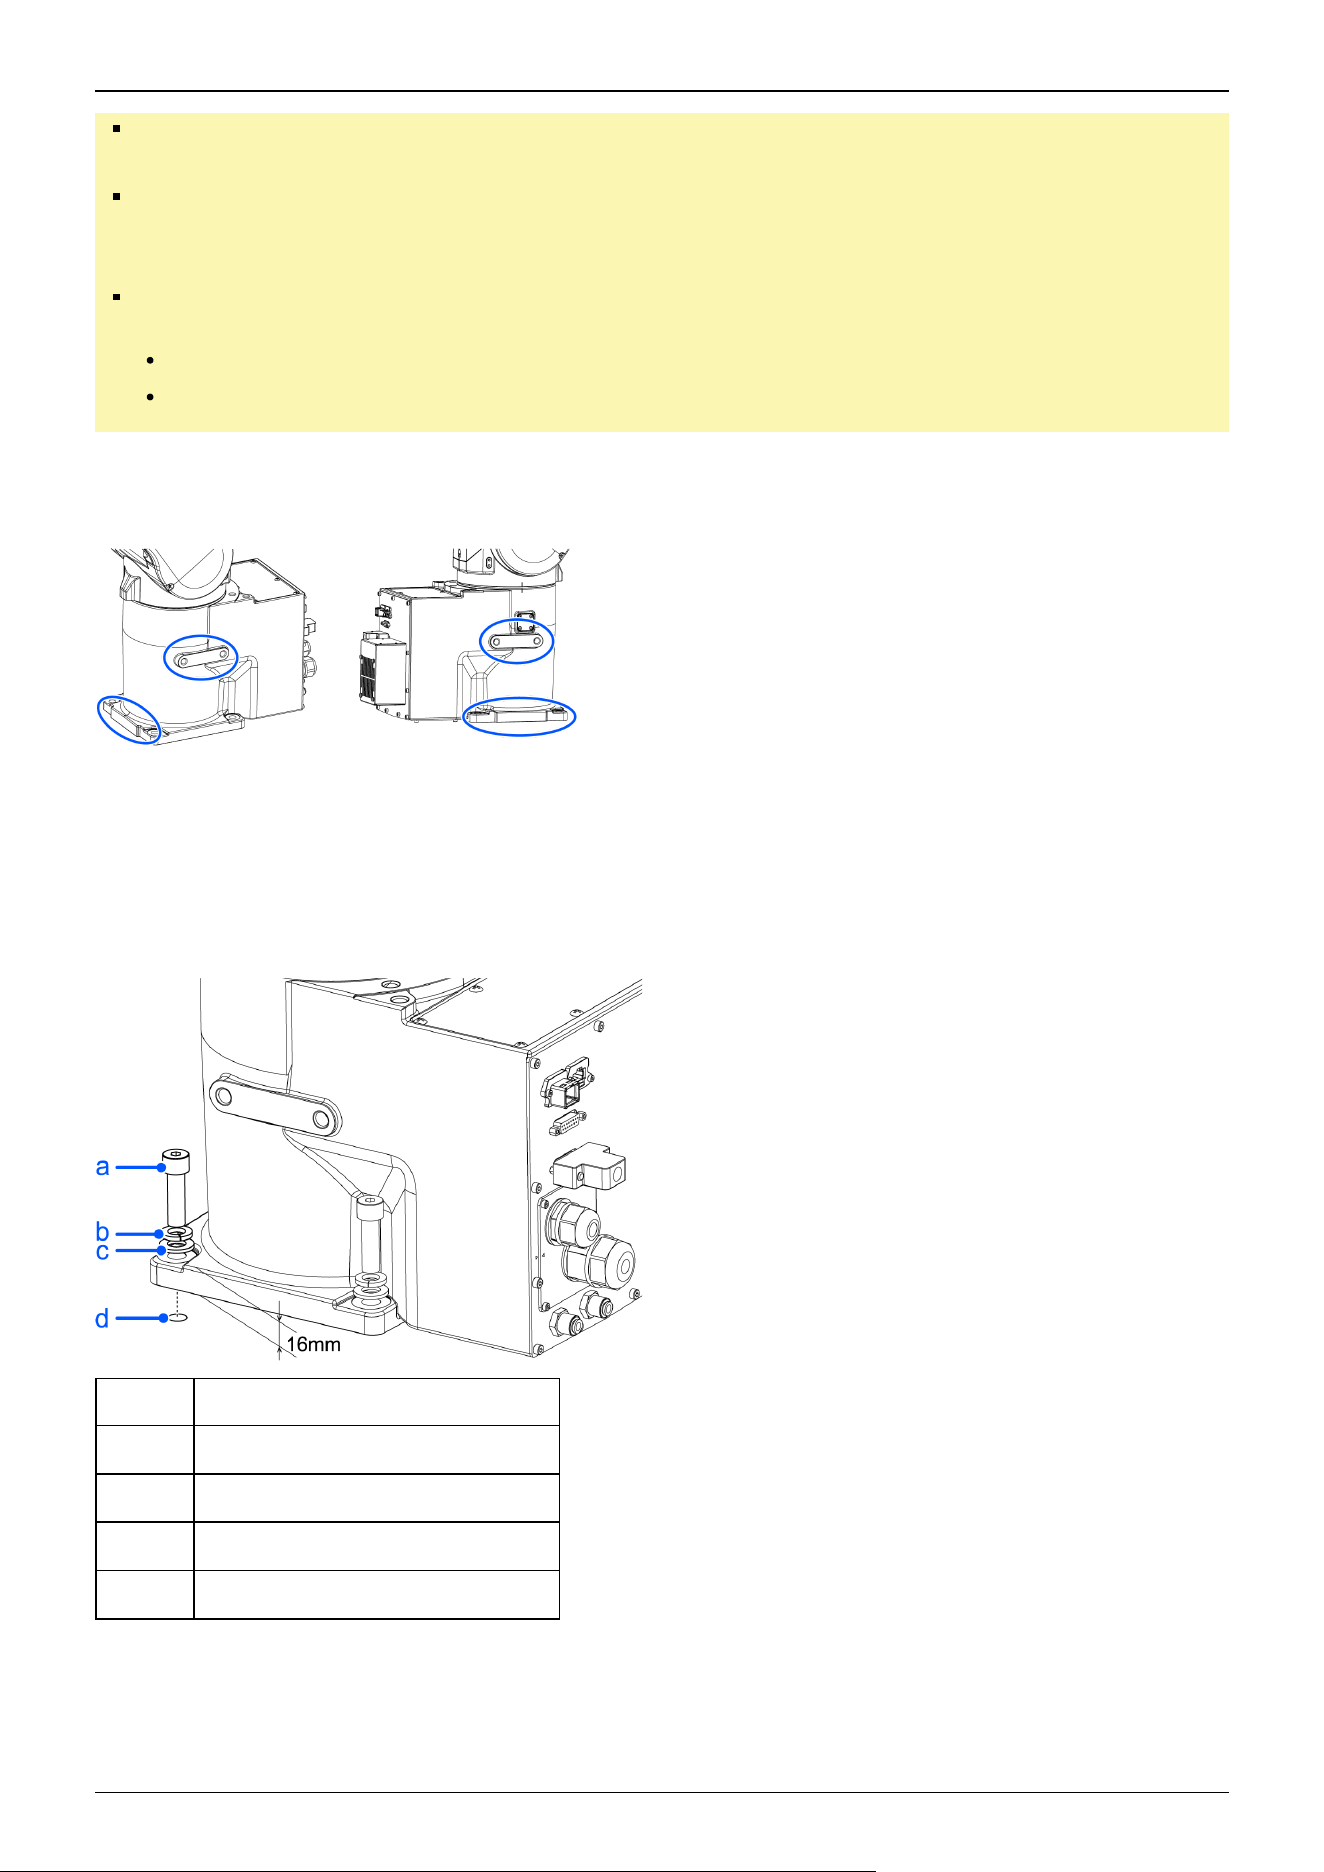
There are four threaded holes for the Manipulator base. Use M12 mounting bolts conforming to the strength equivalent to
ISO898-1 property class 10.9 or 12.9. Tightening torque: 100.0 ± 5.0 N·m (1,020 ± 51 kgf·cm)
Symbol Description
a 4×M12×40
b Spring washer
c Plain washer
d Threaded hole (25 mm or more depth)
Base table
A base table for anchoring the Manipulator is not supplied. The base table must be fabricated or obtained by the customer.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
37
The shape and size of the base table vary depending on the application of the robot system. As a reference when designing the
base table, the requirements from the Manipulator side are shown here.
The base table must not only be able to bear the weight of the Manipulator but also be able to withstand the dynamic
movement of the Manipulator when it operates at maximum acceleration/deceleration. Ensure that there is enough strength on
the base table by attaching reinforcing materials such as crossbeams.
Followings are the torque and reaction force produced by the movement of the Manipulator.
Model Number C8-C901 *** C8-C1401***
Model Name C8L C8XL
Maximum rotating torque on horizontal surface (N·m) 1800 2600
Maximum reaction force in horizontal direction (N) 1300 1300
Maximum rotating torque on vertical surface (N·m) 2200 3400
Maximum reaction force in vertical direction (N) 6000 7800
The plate for the Manipulator mounting face should be at least 30 mm thick and made of steel for reducing vibrations.
A surface roughness of 25 μm or less at the maximum height is appropriate.
The base table must be secured on the floor to prevent it from moving.
The Manipulator installation surface should have a flatness of 0.5 mm or less and an inclination of 0.5° or less. If the
installation surface does not have the proper flatness, the base of the Manipulator may be damaged or the robot may be unable
to operate at maximum performance.
When using a leveler to adjust the height of the base table, use a screw with M16 diameter or more.
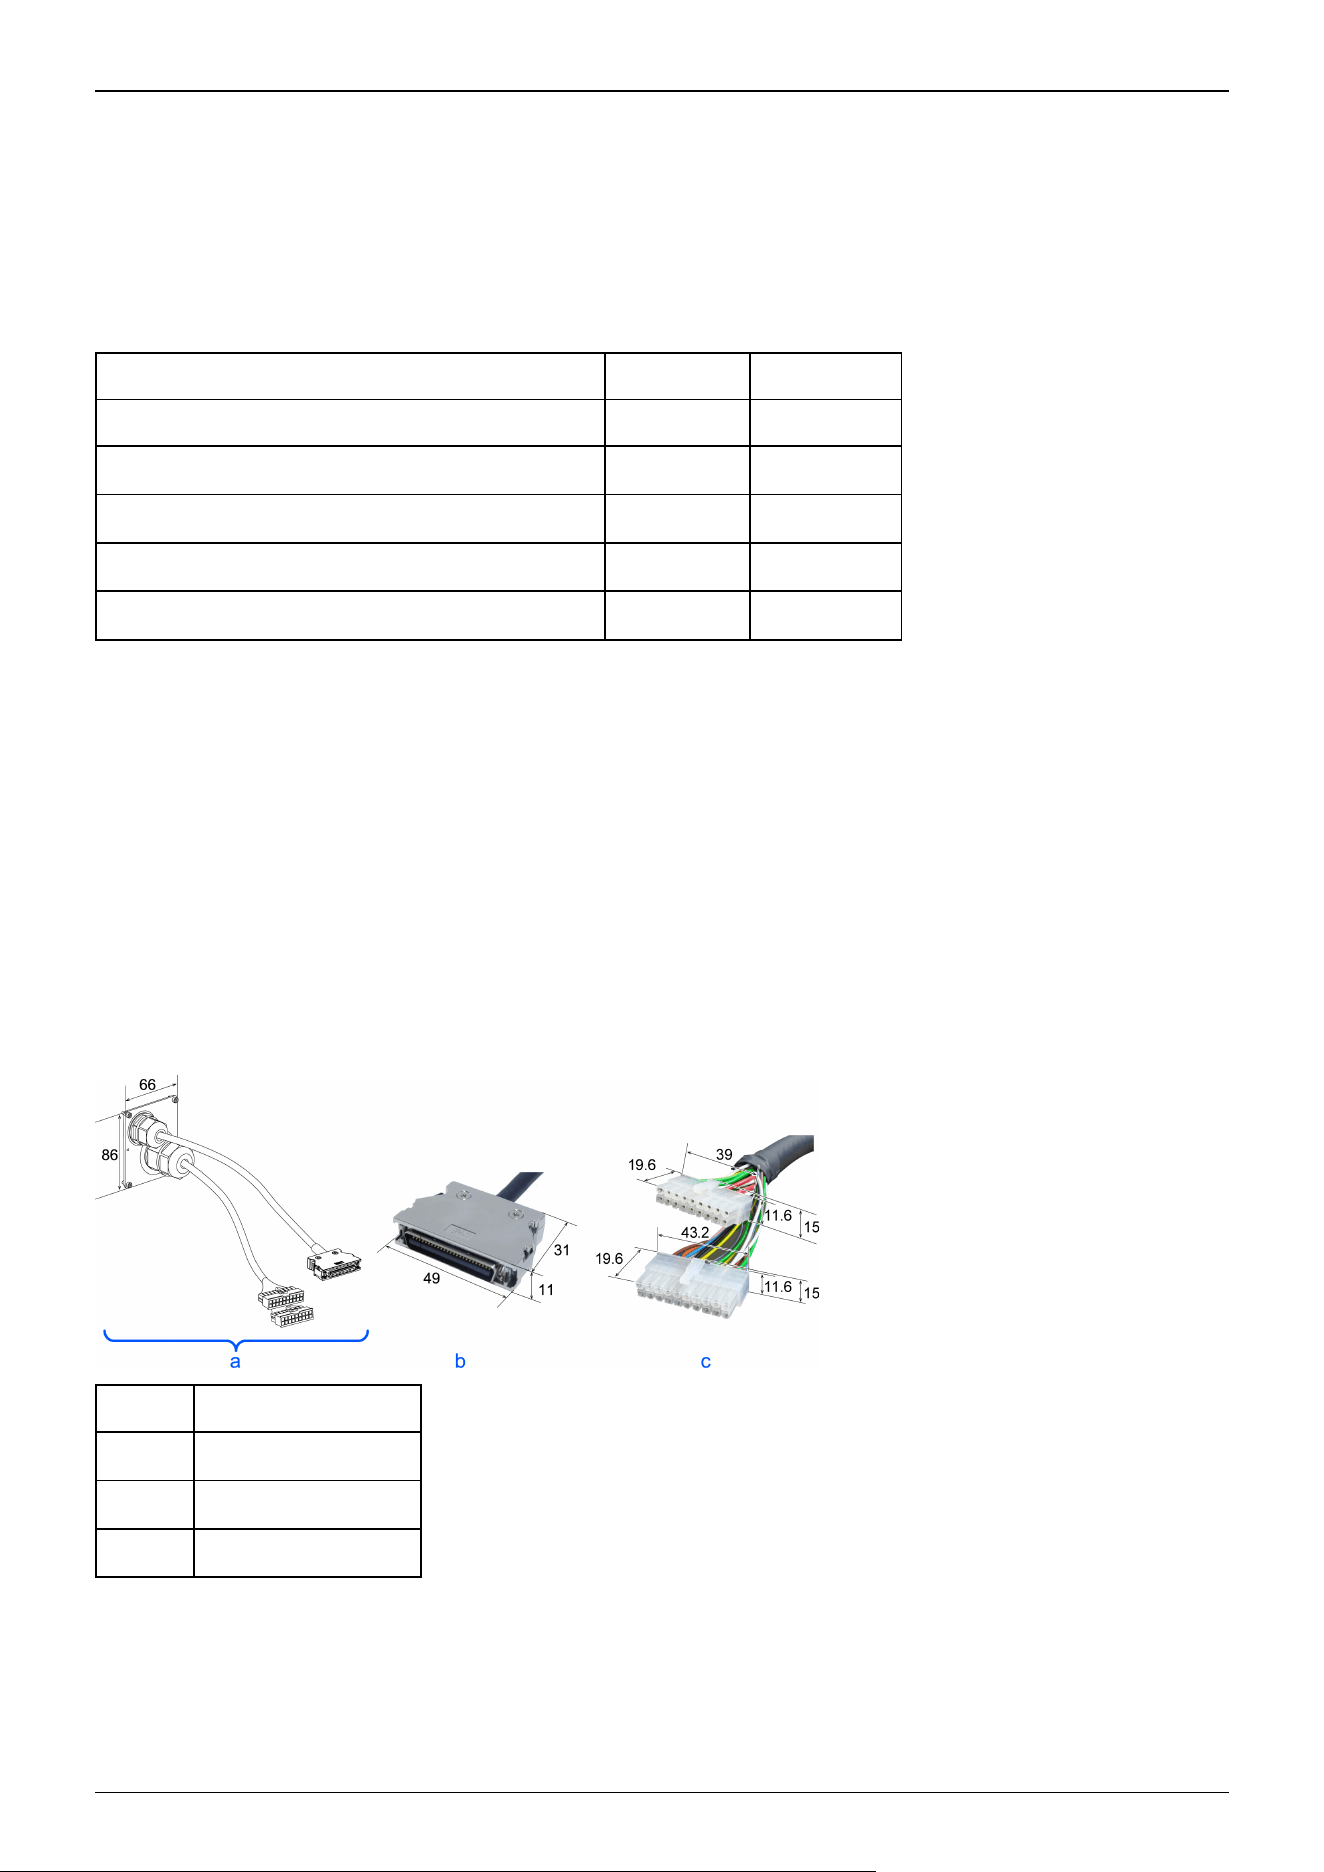
Connector
If passing cables through the holes in the base table, refer to the connector dimensions in the figures below. (Units: mm)
Symbol Description
a M/C cable
b Signal cable connector
c Power cable connector
Do not remove the M/C cables from the Manipulator.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
38
KEY POINTS
For details on the environmental requirements for the space when housing the Controller in the base table, refer
to the Robot Controller manual.
When using the Manipulator in the clean room, follow the steps below before the installation.
1. Unpack the Manipulator outside of the cleanroom.
2. Secure the Manipulator to transporting equipment (or a pallet) with bolts so that the Manipulator does not fall down.
3. Wipe off any dust on the Manipulator using a lint-free cloth that was dipped in ethyl alcohol or distilled water.
4. Carry the Manipulator into the cleanroom.
5. Secure the Manipulator to the base table.
2.3.4 Connecting the Cables
WARNING
Before performing any replacement work, turn off the Controller and related equipment, and unplug the power
cable from the power source. Performing any work procedure with the power turned on is extremely
dangerous and may result in electric shock and/or malfunction of the robot system.
Be sure to connect the AC power cable to a power outlet. Do not connect it directly to a factory power source.
To perform the power supply lockout, remove the power plug. Working while connecting the AC power cable
to a factory power source may result in electric shock and/or malfunction of the robot system.
Be sure to connect the cables properly. Do not put heavy objects on the cables, bend or pull on the cables
forcibly, or allow the cables to be pinched. Damaged cables, broken wires, or contact failure is extremely
hazardous and may result in electric shock and/or malfunction of the robot system.
Be sure to turn off the power and tag out (e.g., with a "DO NOT TURN ON" sign) before performing wiring.
Performing any work procedure with the power turned on is extremely dangerous and may result in electric
shock and/or malfunction of the robot system.
The Manipulator is grounded by connecting it to the Controller. Ensure that the Controller is grounded and the
cables are correctly connected. If the ground wire is improperly connected to ground, it may result in the fire
or electric shock.
Turn off the power to the Robot Controller and brake release unit when connecting or replacing the brake
release unit or external short connector. Inserting or removing connectors with the power on may result in
electric shock and/or malfunction of the robot system.
CAUTION
When connecting the Manipulator and the Controller, check that the serial numbers match for each device.
Improper connection between the Manipulator and the Controller may not only lead to malfunction of the robot
system but also safety problems. The connection method between the Manipulator and the Controller varies
depending on the Controller. For details on the connection, refer to the following manual.
"Robot Controller Manual"
Only authorized or certified personnel should perform wiring. Wiring by unauthorized or uncertified staff may
result in bodily injury and/or malfunction of the robot system.
Operating the Manipulator without a brake release unit or external short connector connected may cause the
brake to fail to release, possibly damaging the brake.
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
39
After using the brake release unit, be sure to connect the external short circuit connector to the Manipulator or
make sure to leave the connector for the brake release unit connected.
Cleanroom-model Manipulator
When the Manipulator is a model with cleanroom specifications, an exhaust system must be connected. For the exhaust
system, refer to the following section.
C8 Specifications
Protected-model Manipulator
When the Manipulator is a protected-model, please note the following points.
CAUTION
When operating Manipulators in special environments (oil smoke, dust, etc.), do not install the Controller in
the same environment. The Controller does not satisfy the protection class (IP67). Using the Controller in
these special environments may damage or lead to a breakdown of the Controller.
After using the brake release unit, be sure to reconnect the external short connector to the Manipulator. The
break release unit does not satisfy the protection class (IP67).
Be sure to connect a connector compliant with protection class IP67 or higher and a connector cover to the
Ethernet cable connector.
Connection procedure for M/C cable
Connect the power connector and signal connector of the M/C cable to the Controller.
2.3.5 User Wires and Pneumatic Tubes
CAUTION
Only authorized or certified personnel should perform wiring. Wiring by unauthorized or uncertified staff may
result in bodily injury and/or malfunction of the robot system.
User electrical wires and pneumatic tubes are contained in the cable unit.
Cable backward model
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
40
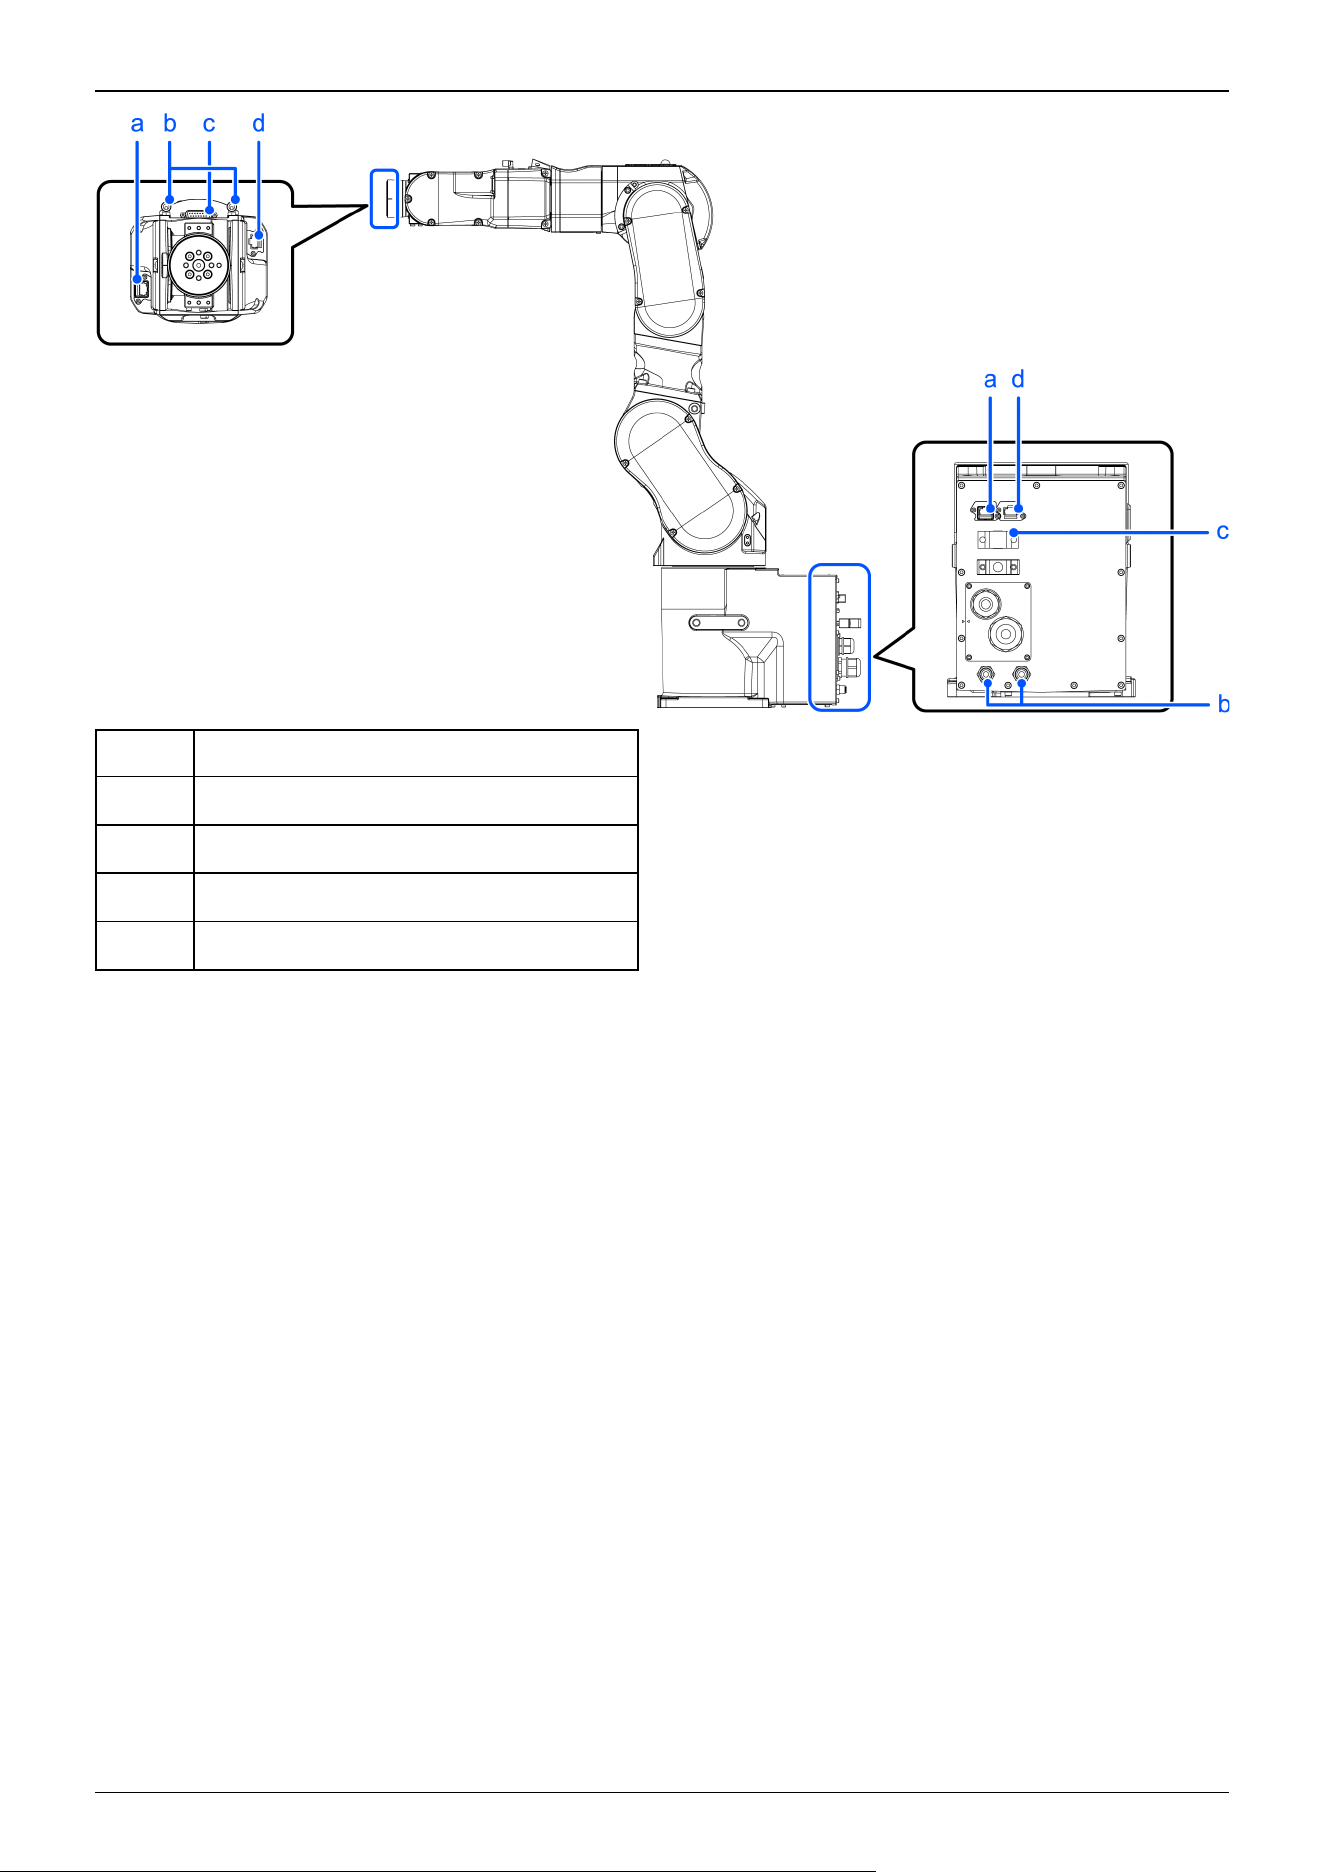
Symbol Description
a Force Sensor cable connector
b Fitting for ⌀6 mm tube (Air1, Air2)
c User cable connector (15-pin D-sub connector)
d Ethernet cable connector
Cable downward model
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
41
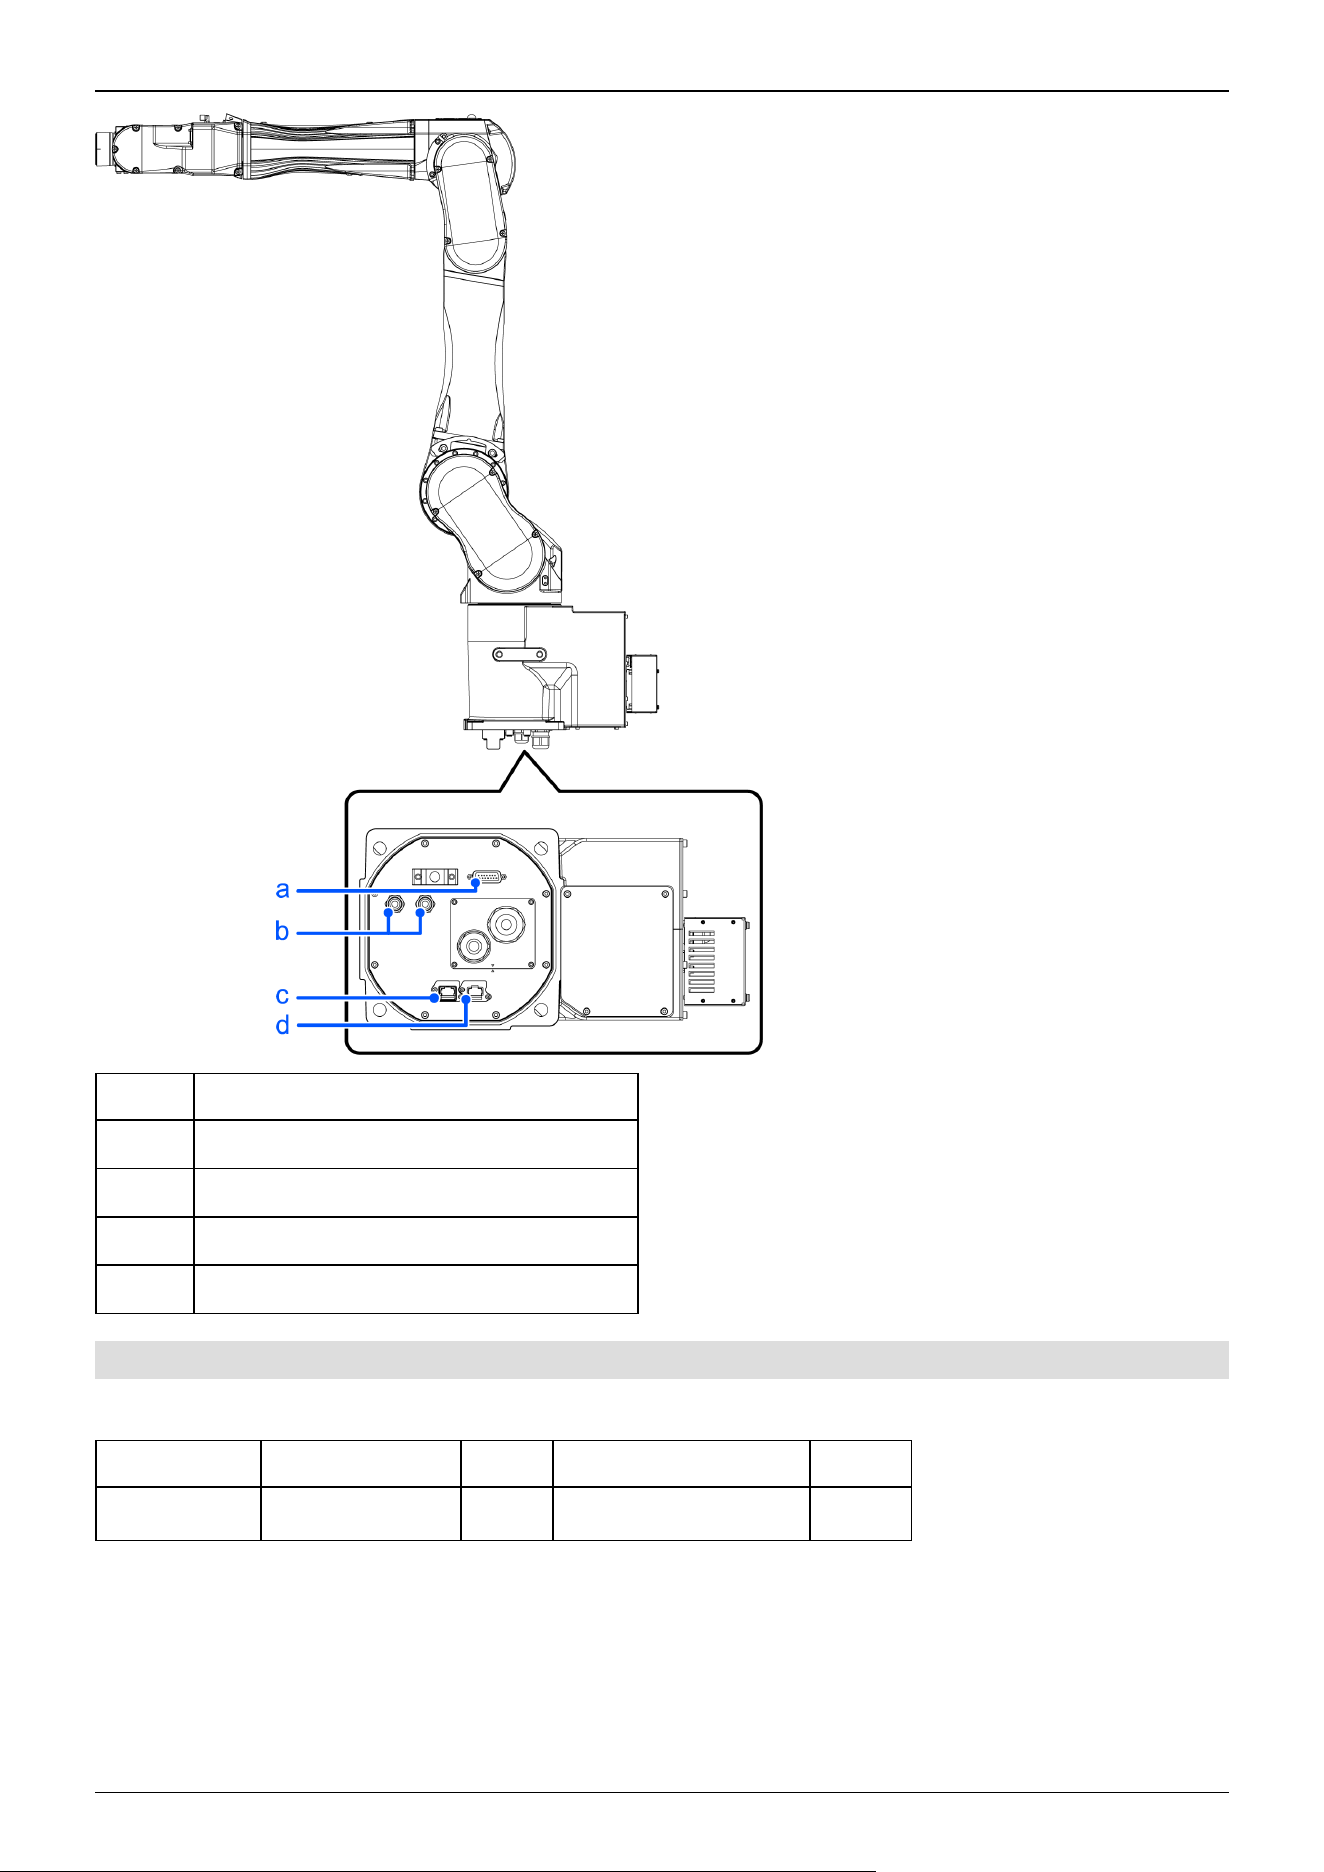
Symbol Description
a User cable connector (15-pin D-sub connector)
b Fitting for ⌀6 mm tube (Air1, Air2)
c Force Sensor cable connector
d Ethernet cable connector
2.3.5.1 Electrical Wires
Specifications of the user wires D-sub 15-pin
Rated Voltage Allowable Current Wires Nominal Sectional Area Note
AC/DC30V 1 A 15
0.106 mm
2
Shielded
Pins with the same number, indicated on the connectors on both ends of the cables, are connected.
Attached connector for user wires (standard, cleanroom model)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
42
Manufacturer Type
15 pin
Connector JAE DA-15PF-N (Solder type)
Clamp hood HRS HDA-CTH (4-40) (10) (Connector setscrew: #4-40 UNC)
Two parts are attached for each.
Attached connector for user wires (protected-model)
Manufacturer Type
15 pin
Connector HARTING 09 67 015 5615 (Solder type)
Clamp hood HARTING 09 67 015 0538 (Connector setscrew: #4-40 UNC)
Two parts are attached for each.
8-pin (RJ45) equivalent to Cat.5e
An Ethernet cable (commercially available) can be connected to Manipulator models with standard and cleanroom
specifications.
For the protected-model, use the following optional part.
User connector kit (IP67 waterproof, for RJ45, 2 pcs)
For details, refer to the following section.
Options
Other
The 6-pin cable for the Force Sensor option is included.
2.3.5.2 Pneumatic Tubes
Maximum Working Pressure Number of Tubes Outer Diameter × Inner Diameter
0.59 MPa (6 kgf/cm
2
: 86 psi)
2 ⌀6 mm × ⌀4 mm
Standard model, Cleanroom model:
The elbow fitting is attached on the Arm #4 at the time of shipment. The part can be replaced with the straight fitting
(accessory) according to application.
Protected-model:
The plugs are installed on the Arm #4 and the base. To use the pneumatic tubes, remove the plugs and install the fittings
(accessory) on the Arm #4.
Threaded hole size for installing the Arm #4 fitting: M6
When the Manipulator is a protected-model, please note the following points.
CAUTION
In special environments (e.g., oil smoke, dust, etc.), the user wires and pneumatic tubes should have
protected-model (compliant with protection class IP67). If the user wires and pneumatic tubes not protected-
model are connected, the protection class (IP67) cannot be guaranteed, and the Manipulator may be
damaged or break down.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
43
Be sure to attach the cap or plug (attached at the time of shipment) on the user cable connector when not
using the user cable connector or the pneumatic tubes. Using the Manipulator without the cap or plug may
cause equipment damage to and/or malfunction of the Manipulator as dust or oily smoke gets into the
connector.
2.3.6 Checking the Basic Orientation
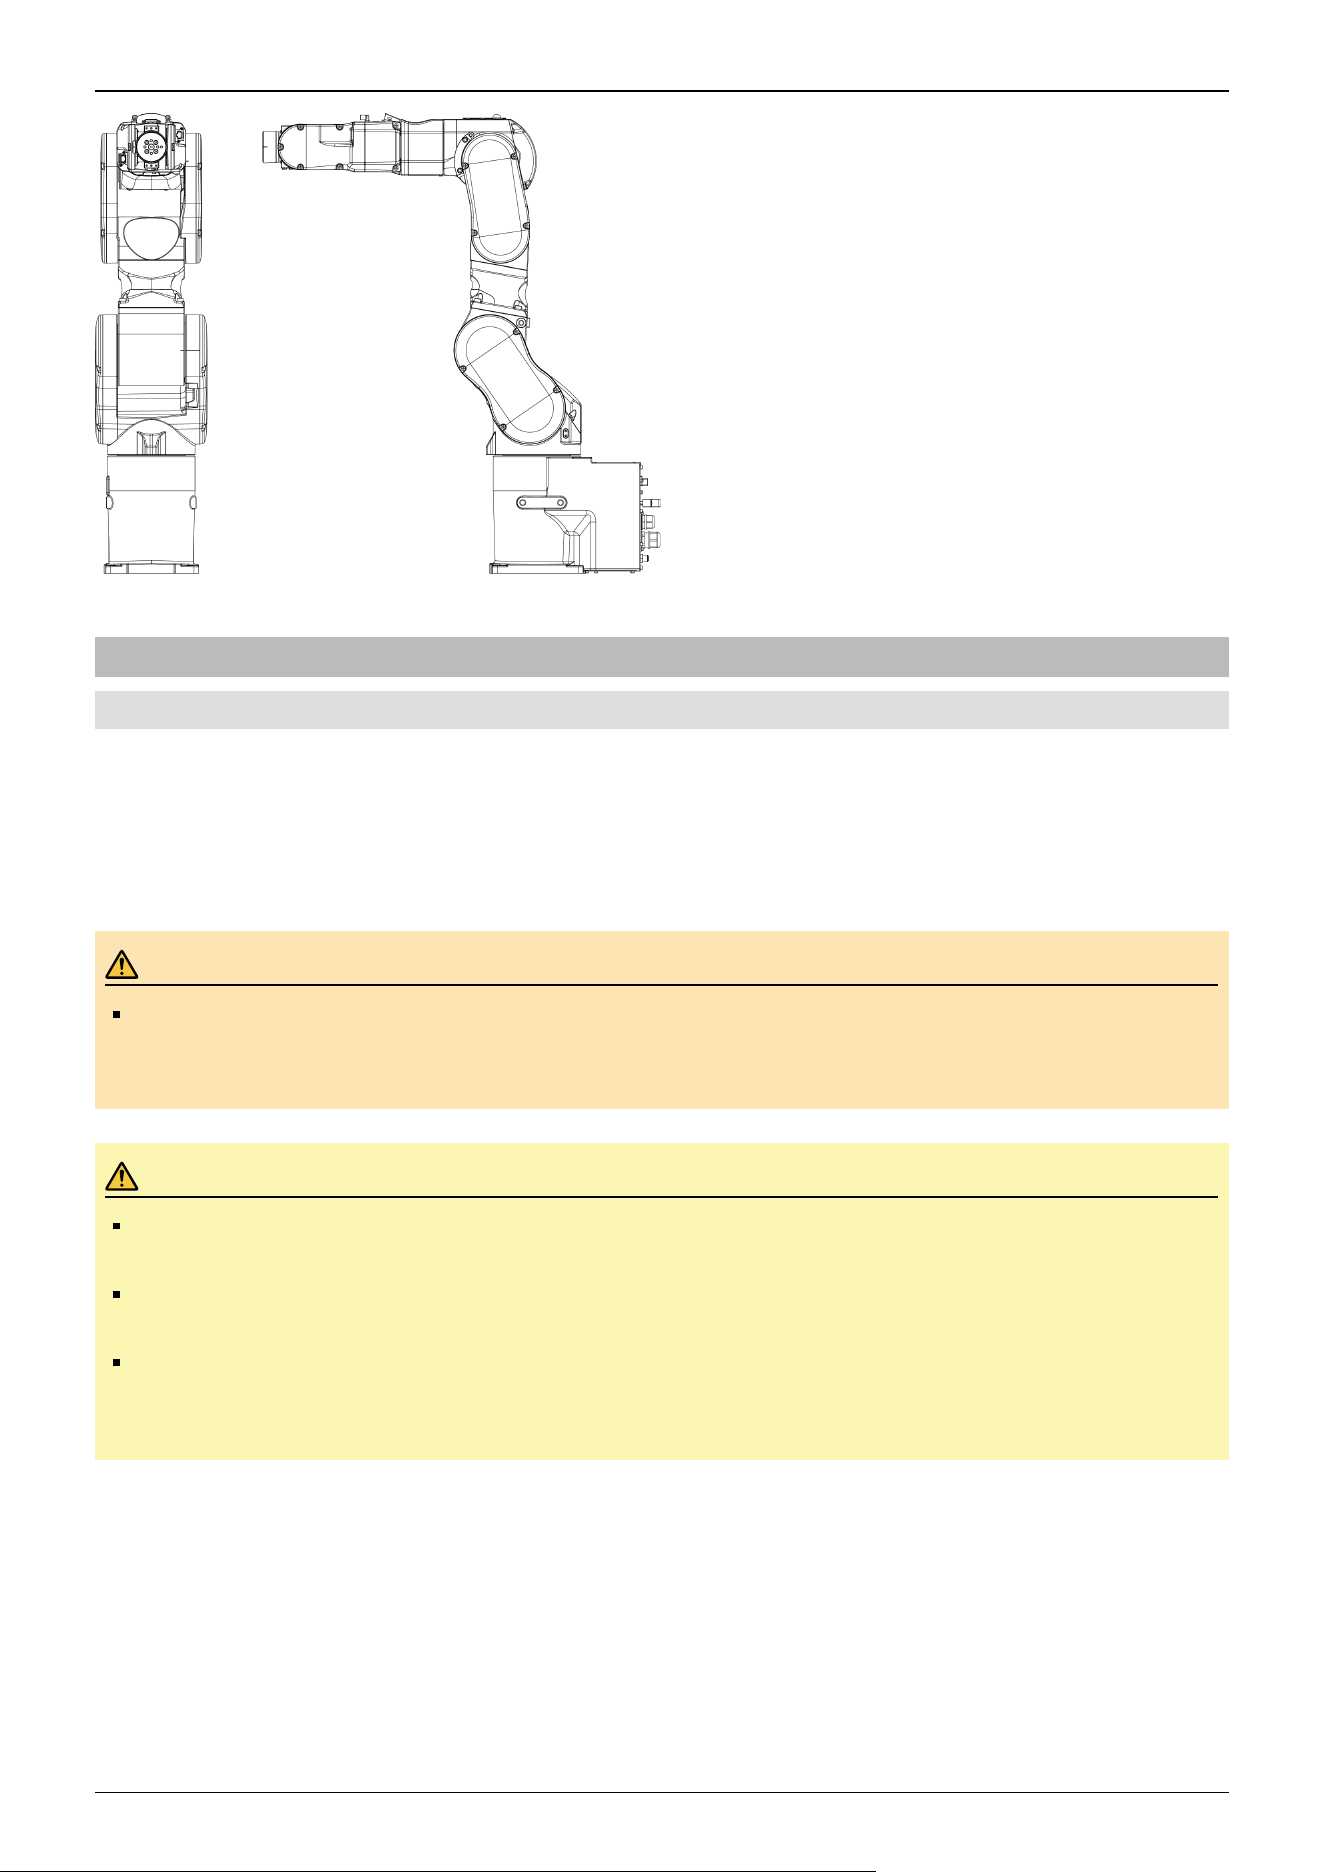
After installing the Manipulator and setup the operating environment, check if it moves to the basic position properly.
Follow the steps below to set the basic orientation of the Manipulator shown below as the origin position.
1. Start Epson RC+.
Double click the [Epson RC+] icon on the desktop.
2. Open the command window.
Epson RC+ menu-[Tools]-[Command Window]
3. Execute the following command in [Command Window].
>Motor On
>Go Pulse (0,0,0,0,0,0)
KEY POINTS
If "Error 4505: cannot be turned on the motor because the Safety Board is issuing a stop signal." occurs, use one
of the following methods to move the Manipulator to its basic orientation.
Release the brake and push the arm by hand to move it within the motion range. Then follow the steps above.
For details on releasing brake, refer to the following section.
How to Move Arms with the Electromagnetic Brake
Press the TP3 or TP4 command button [Pulse0] to move the Manipulator to its basic orientation. For details,
refer to the following manuals.
For TP3:
"Robot Controller Option Teach Pendant TP3 Operation 3.1.3 Command Buttons"
For TP4:
"Robot Controller Option Teach Pendant TP4 3.2.5.13.2 Command Buttons"
"Robot Controller Option Teach Pendant TP4 3.2.9.7.2 Command Buttons"
If the Manipulator cannot be in the basic orientation shown below, please contact the supplier.
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
44
2.3.7 Relocation and Storage
2.3.7.1 Safety Information for Relocation and Storage
Pay attention to the following requirements when relocating, storing, and transporting the Manipulators.
Transportation and installation of the Manipulator and related equipment should be performed by people who have received
installation training provided by Epson and the suppliers. Also, the laws and regulations of the installation country must be
followed.
WARNING
Only qualified personnel should perform sling work and operate a crane or a forklift. When these operations
are performed by unqualified personnel, it is extremely hazardous and may result in serious bodily injury
and/or severe equipment damage to the robot system
CAUTION
Before relocating, fold the arm and secure it tightly with a cable tie to prevent hands or fingers from getting
caught in the Manipulator.
When removing the anchor bolts, support the Manipulator so that it does not fall. Removing the anchor bolts
without supporting the Manipulator can cause it to fall, causing hands or feet to get caught.
The Manipulator should be transported by two or more people or secured to transporting equipment. Also, do
not hold the bottom of the base. Holding these parts by hand is extremely hazardous and may cause your
hands and fingers caught.
During unpacking and relocation, avoid applying external force to the arms and motors of the Manipulator.
When transporting the Manipulator over long distances, secure it directly to transporting equipment so that it will not fall. If
necessary, pack the Manipulator using the same packaging as delivery.
When the Manipulator is reassembled and used for a robot system again after an extended period of storage, perform a test run
to verify that it works properly before starting the main operation.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
45
Manipulators should be transported and stored under the following conditions: Temperature: -20 to +60°C, Humidity: 10 to
90% (no condensation)
If condensation has formed on the Manipulator during transportation or storage, do not turn on the power until the
condensation is removed.
Do not subject the Manipulator to excessive impacts or vibrations during the transportation process.
Relocation
Follow the procedures described below when relocating the Manipulator.
1. Turn off the power for all devices and unplug the power cable connector and signal cable connector from the Controller.
Do not remove the M/C cables (power cable and signal cable) from the Manipulator.
KEY POINTS
Remove the mechanical stops if using them to limit the motion range. For details on the motion range, refer to
the following section.
Setting the Work Envelope by Mechanical Stops
2. Unscrew the anchor bolts. Then, remove the Manipulator from the base table.
3. Position the Manipulator as shown in the figure. Then, secure the Manipulator to the transporting equipment or have at
least two people to relocate the Manipulator. (Recommend: Joint #2 +55°. Joint #3 -55°)
The posture is common to all models.
Do not hold the bottom of the base (the screened parts in the figure). Holding these parts by hand is extremely hazardous
and may cause your hands and fingers caught.
Manipulator weight
C8-C901***: C8L C8-C1401***: C8XL
Standard, Cleanroom Model 53 kg: 117 lb 63 kg: 139 lb
Protected-Model 57 kg: 126 lb 66 kg: 146 lb
Using eyebolts
Check that the eyebolts are securely fastened before transporting the Manipulator. After transporting the Manipulator, remove
the eyebolts and keep them for future use.
The eyebolts (accessory, 2 pcs) and wire must be strong enough to withstand the weight (See the figures below).
If you use the eyebolts to lift up the Manipulator, make sure to put hands on it to keep the balance. The Manipulator may fall if
the balance is lost and this is extremely hazardous.
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
46
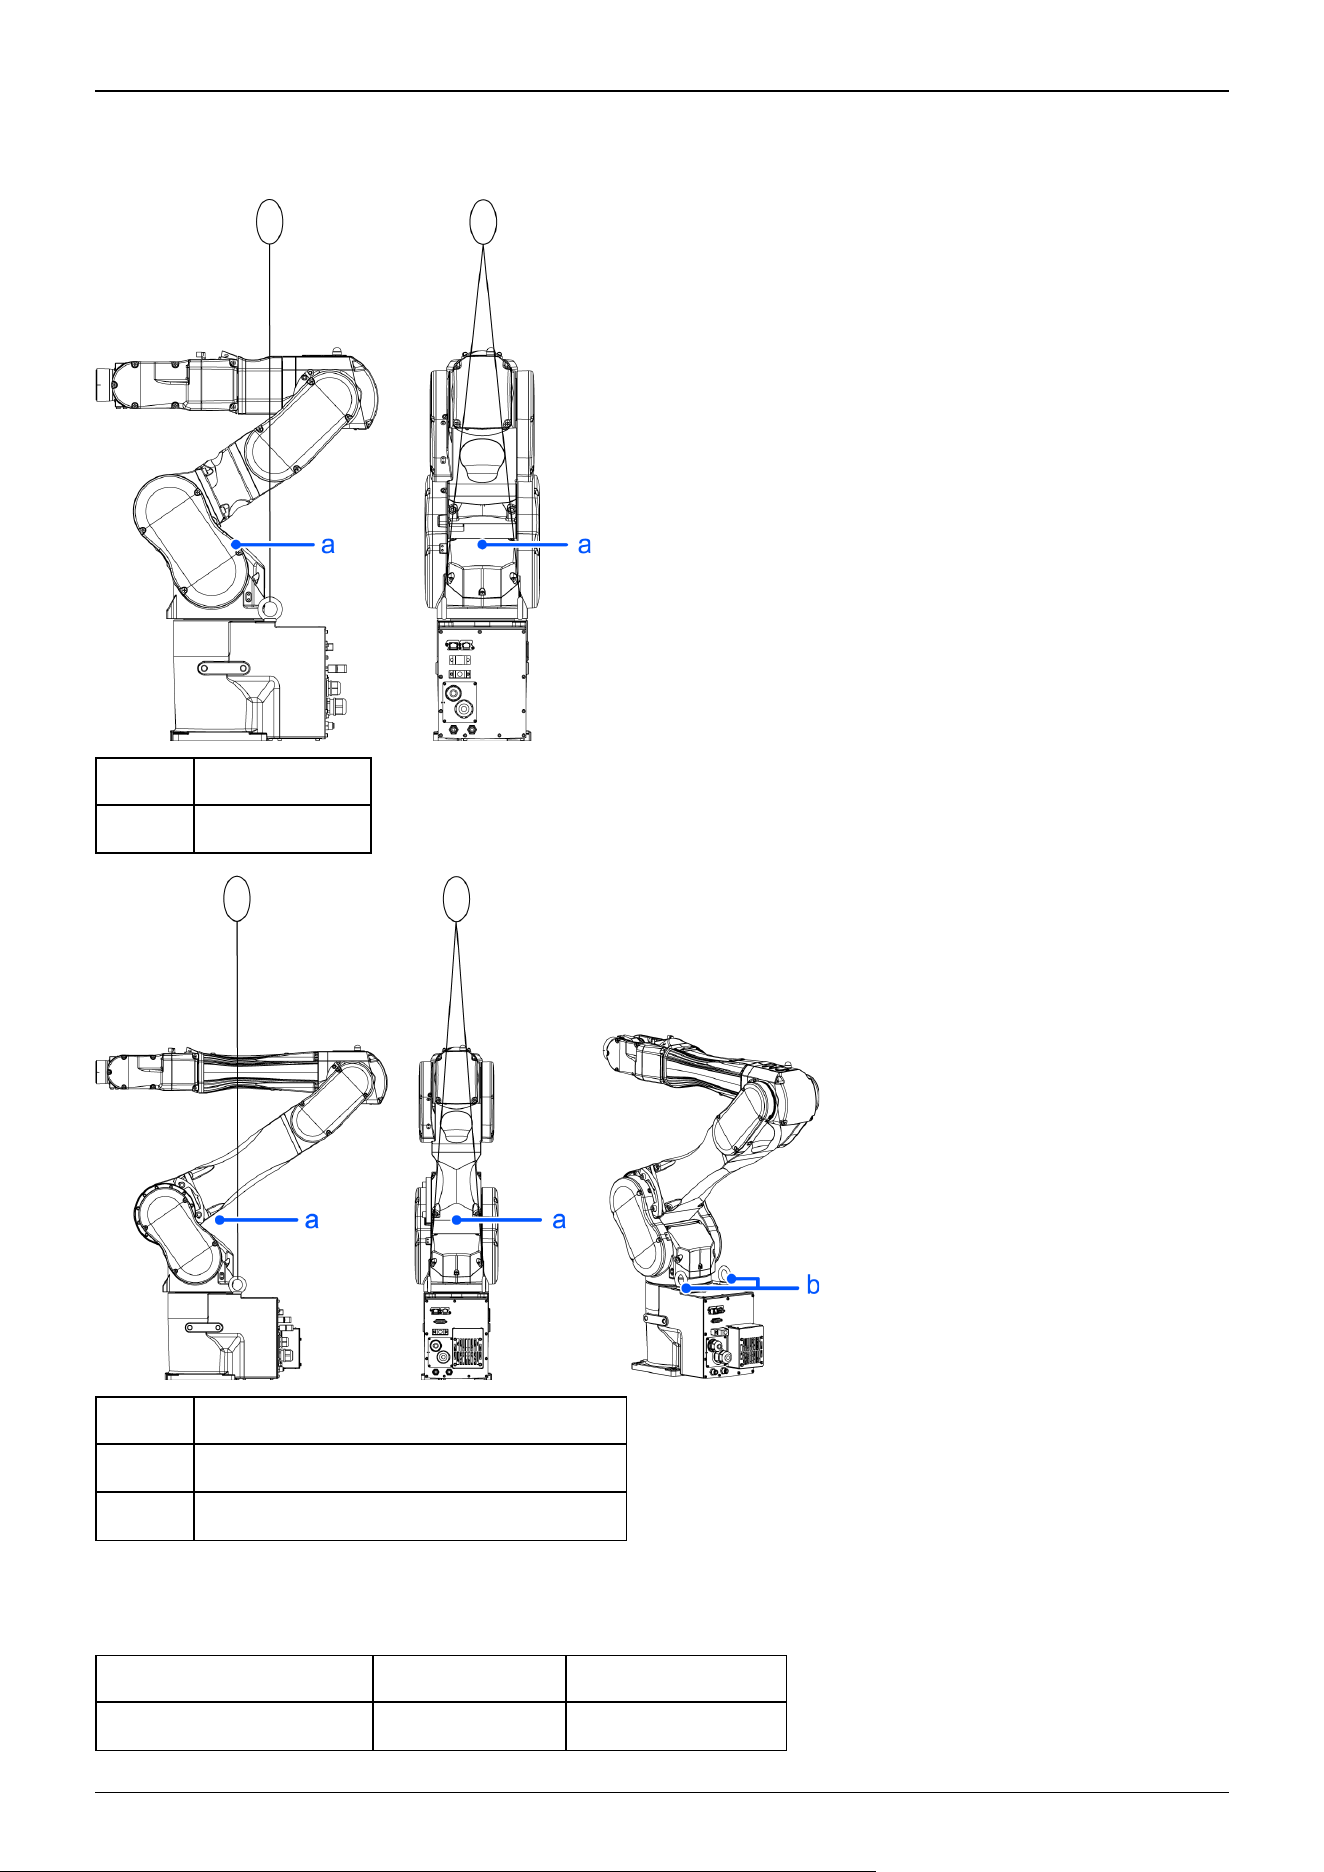
To prevent damage on the covers and arms, it is recommended to protect the contacting parts of the wire and arm with a cloth.
Be very careful not to damage the covers since they are made of plastic.
Symbol Description
a Center of gravity
Symbol Description
a Center of gravity
b Threaded holes for eyebolts: 2×M12 depth 25
Locations of the threaded holes for eyebolts are common to all models.
Manipulator weight
C8-C901***: C8L C8-C1401***: C8XL
Standard, Cleanroom Model 53 kg: 117 lb 63 kg: 139 lb
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
47
C8-C901***: C8L C8-C1401***: C8XL
Protected-Model 57 kg: 126 lb 66 kg: 146 lb
CAUTION
Remove the eyebolts from the Manipulator after transportation/relocation is completed. If the Manipulator is
operated with the eyebolts left on it, the arm may collide with the eyebolts and it may cause equipment
damage to and/or malfunction of the Manipulator.
2.4 Setting the Hand
2.4.1 Installing the Hand
The hand (end effector) must be prepared by the customer. For details on attaching the hand, refer to the following manual.
"Hand Function Manual"
Flange dimensions of the wrist attached to the end of Arm #6 is as below.
WARNING
Before attaching a hand or peripheral equipment, be sure to always turn off the Controller and related
equipment and unplug the power cables. Performing any work procedure with the power turned on is
extremely dangerous and may result in electric shock and/or malfunction of the robot system.
CAUTION
When the hand is equipped with a workpiece gripping mechanism, ensure that the wiring and pneumatic
tubes do not cause the hand to release the workpiece when the power is turned off. When the wiring and
pneumatic tubes are not designed for the hand to maintain its grip on the workpiece when the power is turned
off, pressing the emergency stop switch releases the workpiece, which may damage the robot system and the
workpiece.
By default, all I/Os are designed to automatically turn off (0) when the power is shut off, when an emergency
stop is triggered, or by the robot system's safety function.
However, I/Os set with the Hand function does not turn off (0) when executing the Reset statement, or when
performing an emergency stop.
For the risk of the residual air pressure, conduct a risk assessment on the equipment and take the necessary
protective measures.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
48
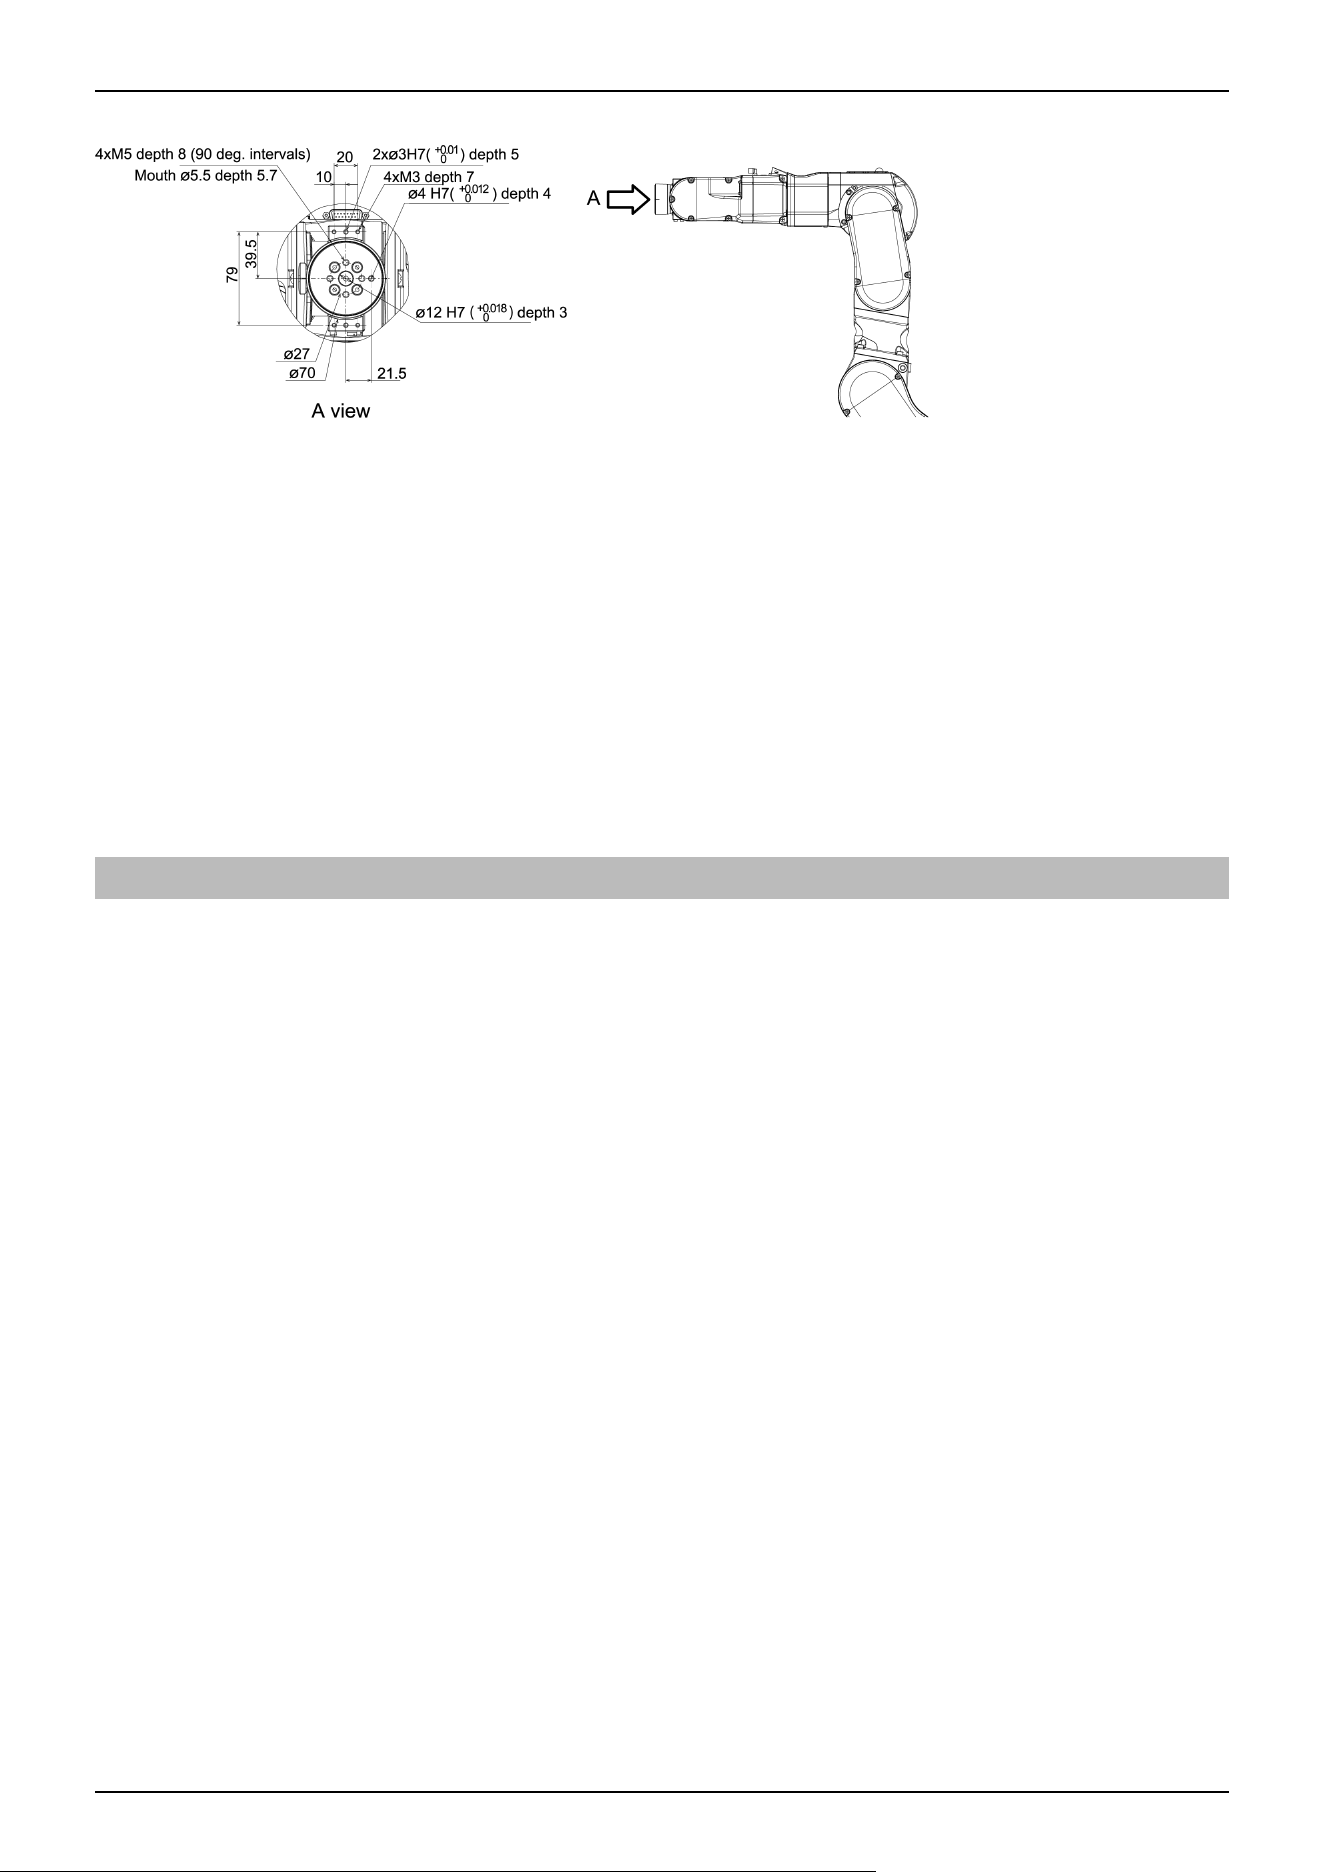
Wrist flange
Arm #6
Attach the hand to the end of the Arm #6 using the M5 bolts.
Layout
When attaching and operating a hand, the hand may come into contact with the Manipulator body due to the outer diameter of
the hand, the size of the workpiece, or the position of the arm. Carefully consider the interference area of the hand when
designing the system layout.
Compatibility with ISO flange
To install the hand whose mounting dimensions are designed for the ISO flange, we provide the optional C8 ISO flange (J6).
For details, refer to the following section.
Options
2.4.2 Attaching Cameras and Valves
Decks are equipped to Arms #3 and #5 to enable the easy installation of air valve. If the payload exceeds the maximum
payload, refer to the following section.
"WEIGHT Setting - Restrictions on payload exceeding the maximum payload"
To mount the camera, the camera plate unit is necessary. We provide the optional Camera Plate Unit. For details, refer to the
following section.
Options
(Units: mm)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
49
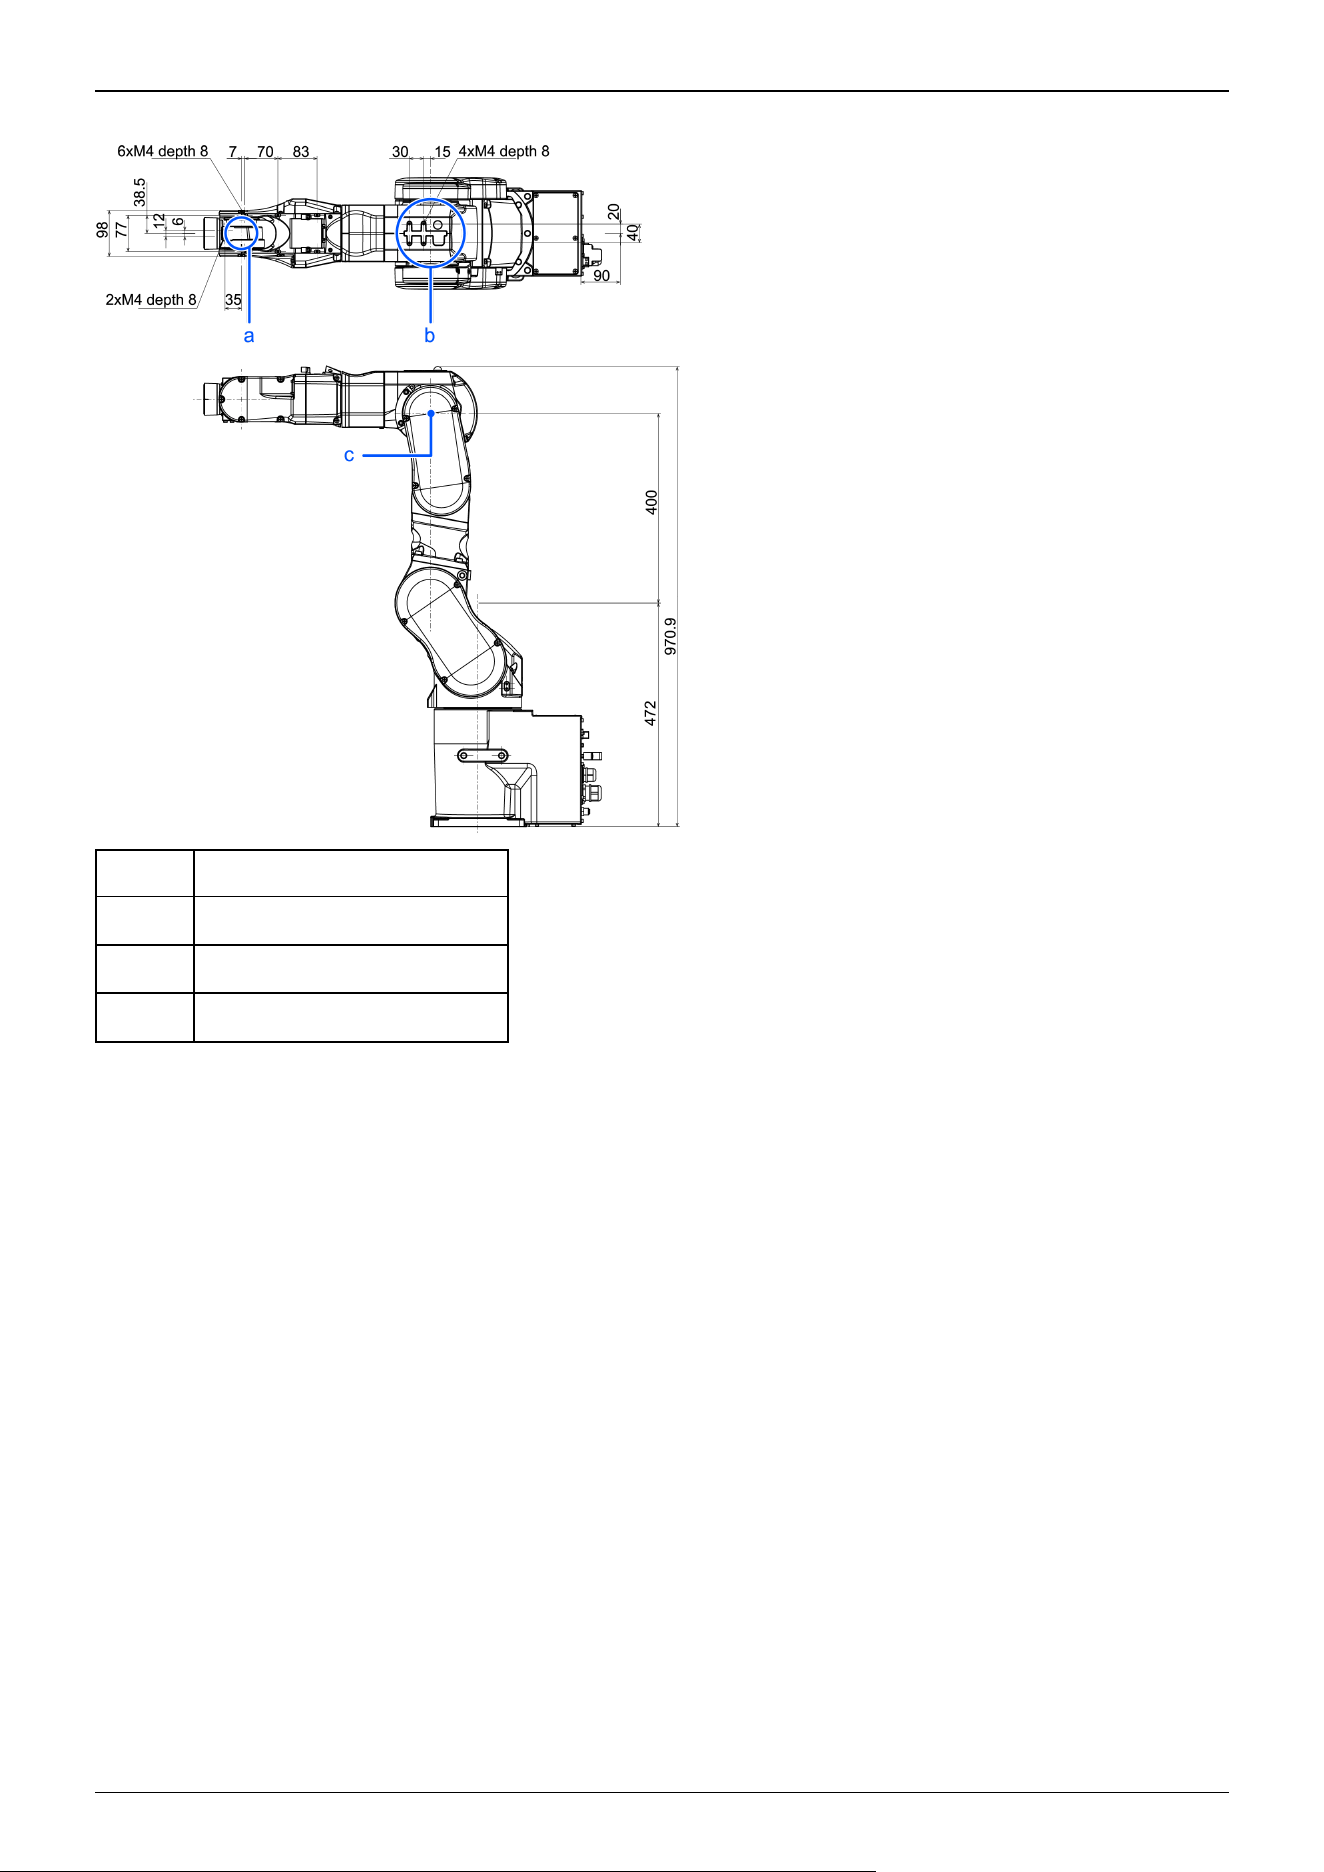
C8-C901*** (C8L)
Symbol Description
a Arm #5 Deck
b Arm #3 Deck
c Rotation center of the upper arm
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
50
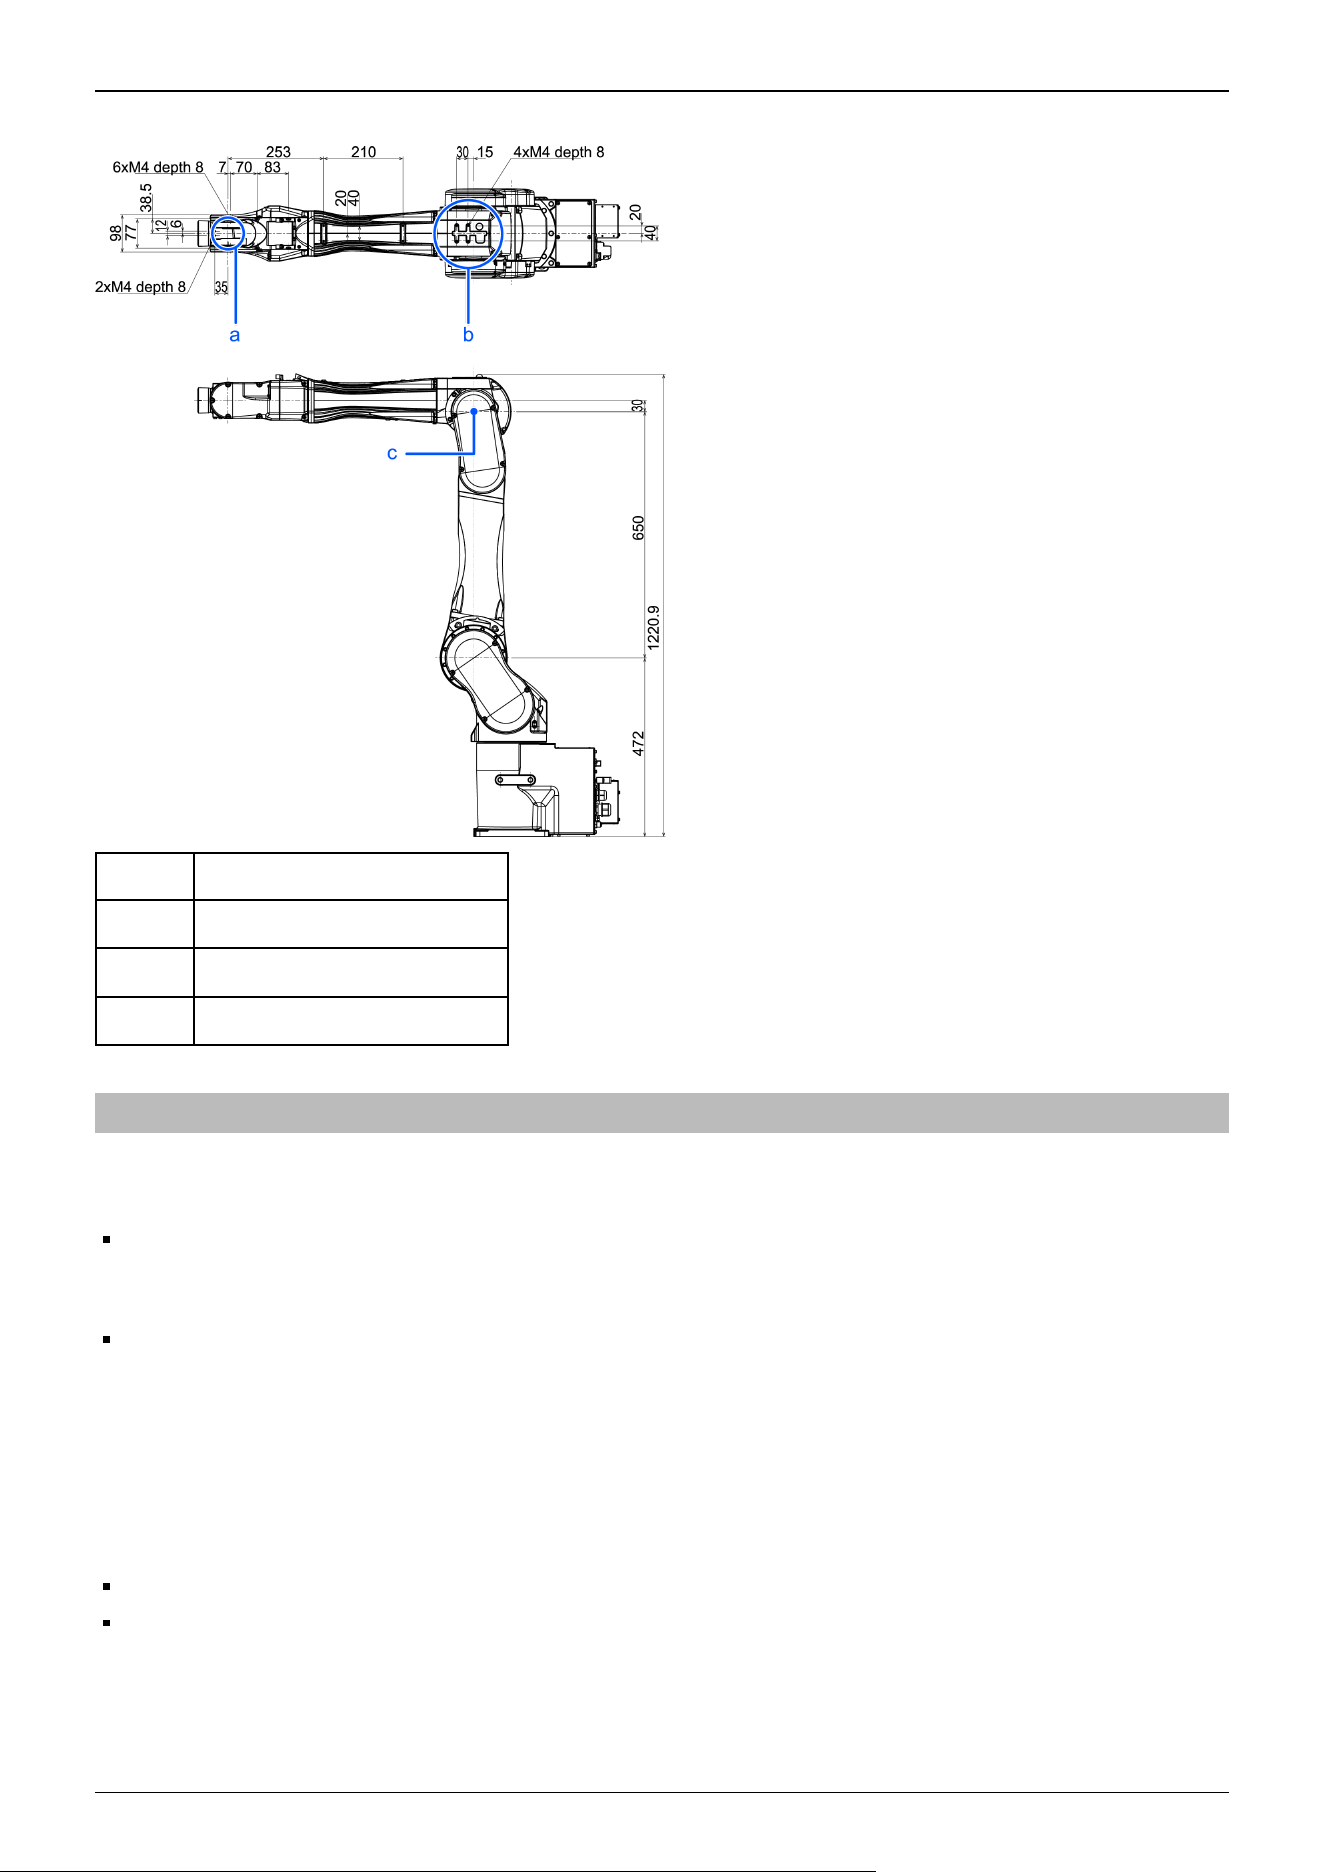
C8-C1401*** (C8XL)
Symbol Description
a Arm #5 Deck
b Arm #3 Deck
c Rotation center of the upper arm
2.4.3 WEIGHT and INERTIA Settings
The WEIGHT and INERTIA commands are for setting the load parameters of the Manipulator. These settings optimize the
Manipulator motion.
WEIGHT Setting
The WEIGHT command is for setting the load weight. The more the load weight increases, the more the speed and
acceleration/deceleration are reduced.
INERTIA Setting
The INERTIA command is for setting the inertia moment and the eccentricity of the load. The more the inertia moment
increases, the more the acceleration and deceleration of the Arm #6 are reduced. The more the eccentricity increases, the
more the acceleration and deceleration for the Manipulator movement are reduced.
To ensure that the Manipulator is functioning properly, keep the load (the sum of the weights of the hand and workpiece) and
the moment of inertia of the load within the rated values, and do not allow for eccentricity from the center of the Arm #6. If the
load or the inertia moment exceeds the ratings or if the load becomes eccentric, follow the steps below to set parameters.
WEIGHT Setting
INERTIA Setting
Setting parameters makes the operation of the Manipulator optimal, reduces vibration to shorten the operating time, and
improves the capacity for larger loads. This also works to curb any persistent vibration that may occur when the hand and
workpiece have a large moment of inertia.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
51
You can also perform settings using the "Weight, Inertia, and Eccentricity/Offset Measurement Utility."
For details, refer to the following manual.
"Epson RC+ User's Guide - Weight, Inertia, and Eccentricity/Offset Measurement Utility"
The allowable load for C8 series Manipulators is up to 8 kg.
Due to the limitations of the moment and moment of inertia shown in the table below, the load (hand + workpiece) should also
meet these conditions.
Allowable Load
Joint Allowable moment
(GD
2
/4) Allowable Moment of Inertia
Joint #4 16.6 N·m (1.69 kgf·m)
0.47 kg·m
2
Joint #5 16.6 N·m (1.69 kgf·m)
0.47 kg·m
2
Joint #6 9.4 N·m (0.96 kgf·m)
0.15 kg·m
2
Moment
The moment indicates amount of torque applied on the joint in order to support the gravity on the load hand + workpiece). The
moment increases as weight of the load and amount of eccentricity increase. As this also increases the load applied on the joint,
make sure to keep the moment within the allowable value.
Moment of inertia
The moment of inertia indicates how difficult the load (hand + workpiece) to rotate when the Manipulator joint starts to rotate
(amount of inertia). The moment of inertia increases as weight of the load and amount of eccentricity increase. As this also
increases the load applied on the joint, make sure to keep the moment within the allowable value.
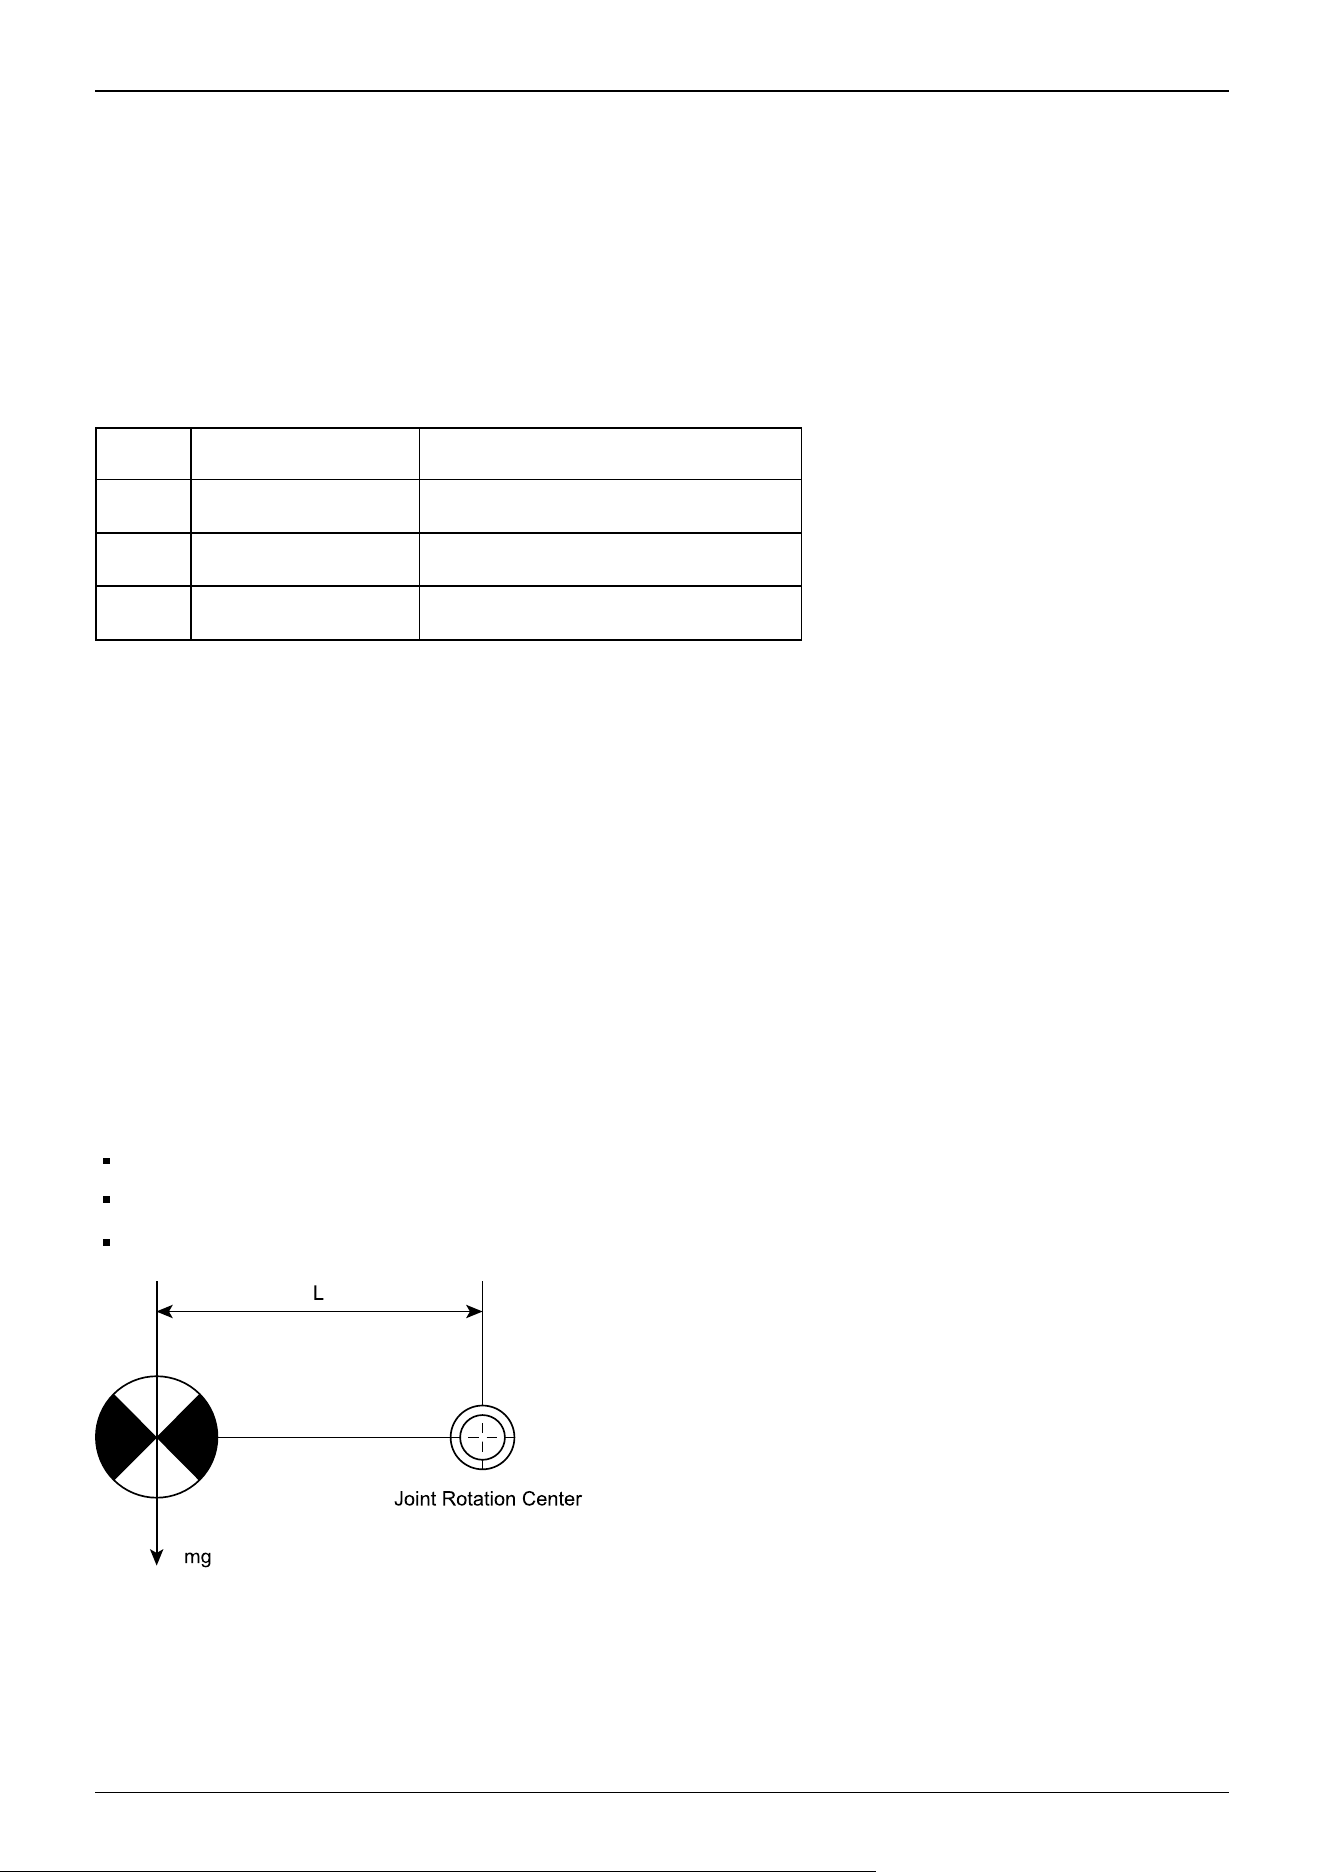
The moment M (Nm) and moment of inertia I (kgm
2
) when the volume of the load (hand + workpiece) is small can be
obtained by the following formula.
M (Nm) = m (kg) × L (m) × g (m/s
2
)
I (kgm
2
) = m (kg) × L2 (m)
m: Weight of load (kg)
L: Eccentricity of load (m)
g: Gravitational acceleration (m/s
2
)
The figure below shows distribution of the center of gravity when the volume of the load (hand + workpiece) is small. Design
the hand so that the center of gravity is within the allowable moment. If the volume of the load is large, calculate the moment
and inertia moment by referring to the following section.
"INERTIA Setting - Calculating the Moment of Inertia"
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
52
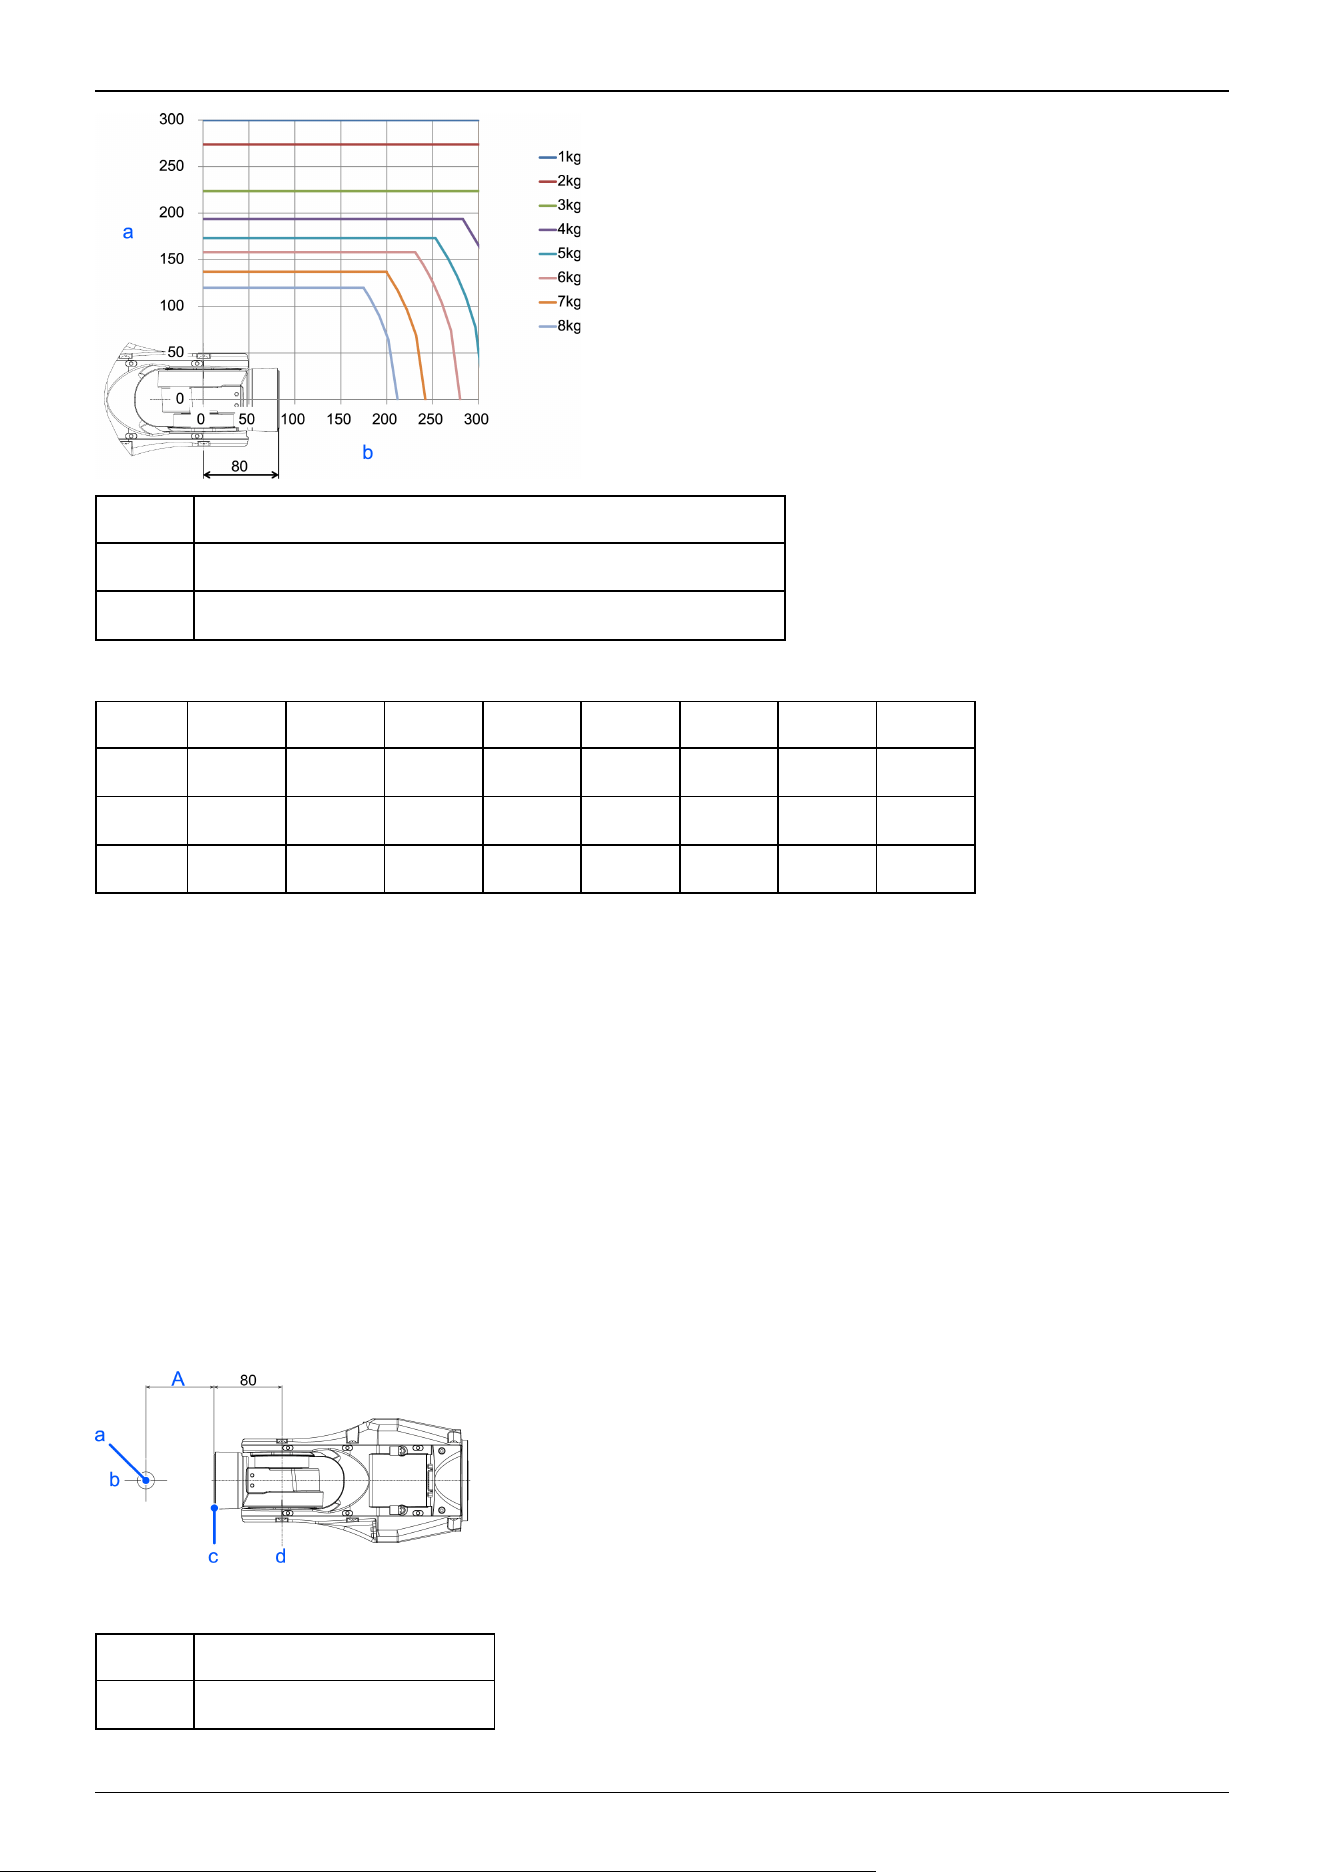
Symbol Description
a Distance from the center of Arm #* rotation [mm]
b Center of gravity of load from the Arm #* rotation center [mm]
Max. Eccentricity of Load (Distance between the joint rotation center and the load’s center of gravity)
Joint 1 kg 2 kg 3 kg 4 kg 5 kg 6 kg 7 kg 8 kg
#4 300 mm 300 mm 300 mm 300 mm 300 mm 280 mm 242 mm 212 mm
#5 300 mm 300 mm 300 mm 300 mm 300 mm 280 mm 242 mm 212 mm
#6 300 mm 274 mm 224 mm 194 mm 173 mm 158 mm 137 mm 120 mm
When calculating the critical dimension of the load using the allowable moment and inertia moment, the calculated value
represents a distance from the Arm #6 rotation center, not the distance from the flange. To calculate the distance from the
flange to the load’s center of gravity, subtract the distance from the center of the Arm #5 rotation center to the flange (=80 mm)
as shown in the example below.
Example: Calculation of the critical dimension of the load (A) when the load is 8 kg.
Center of gravity by the allowable moment control: 16.6 N·m/(8 kg × 9.8 m/s
2
) = 0.212 m = 212 mm
Center of gravity by the allowable inertia moment control: (0.47 kgm
2
/8 kg)1/2 = 0.242 m = 242 mm
Due to the allowable moment control, center of gravity for the load limit is 212 mm from the Arm #5 rotation center.
Distance from the flange to the center of gravity for the load limit A = 212 mm - 80 mm = 132 mm
Critical Dimension of Load
(Units: mm)
Symbol Description
a Load center of gravity position
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
53
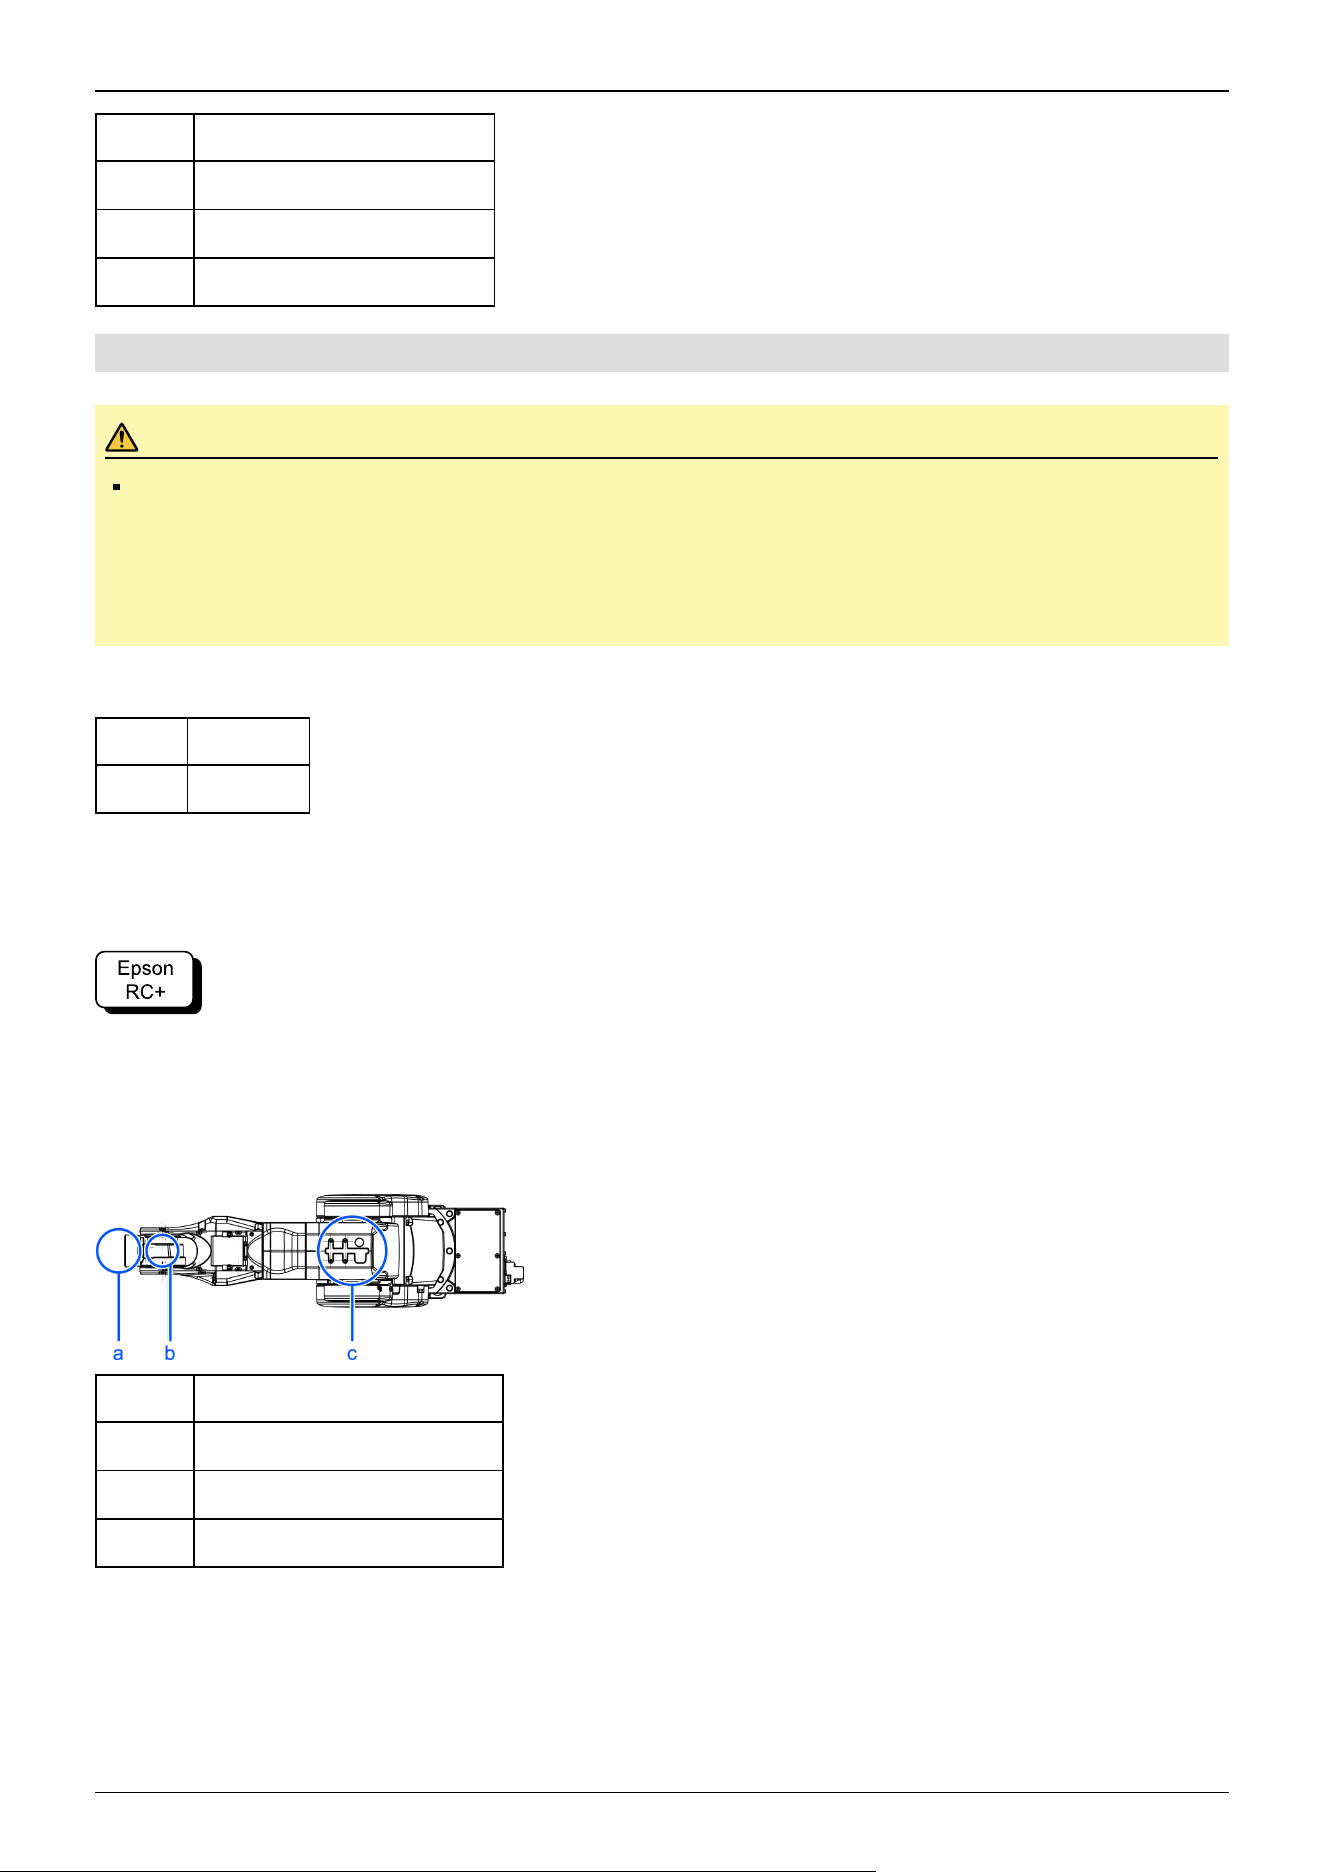
Symbol Description
b Arm #6 rotation center
c Flange
d Arm #5 rotation center
2.4.3.1 WEIGHT Setting
CAUTION
Set the total weight of the hand and the workpiece smaller than the maximum payload. The C8 series
Manipulators can operate without limitations on the condition unless and until the load exceeds this maximum
payload. Always set the Weight parameters of the WEIGHT command according to the load. Setting a value
smaller than the actual weight may cause errors or impact that not only impair full functionality but also
shorten the life of the mechanical components.
The acceptable weight capacity (hand + workpiece) for C8 series Manipulators is as follows:
Rated Maximum
3 kg 8 kg
Change the setting of the Weight parameter according to the load. After changing the Weight parameter setting, the maximum
acceleration/deceleration and speed of the robot system is set automatically.
Setting method of Weight parameters
Select [Tools]-[Robot Manager]-[Weight] panel and set the value in [Weight:]. You may also execute the Weight
command from [Command Window].
Load on the Manipulator
Mounting location of the load
C8-C901*** (C8L)
Symbol Description
a Load on the fore end of Arm #6
b Arm #5 deck
c Arm #3 deck
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
54
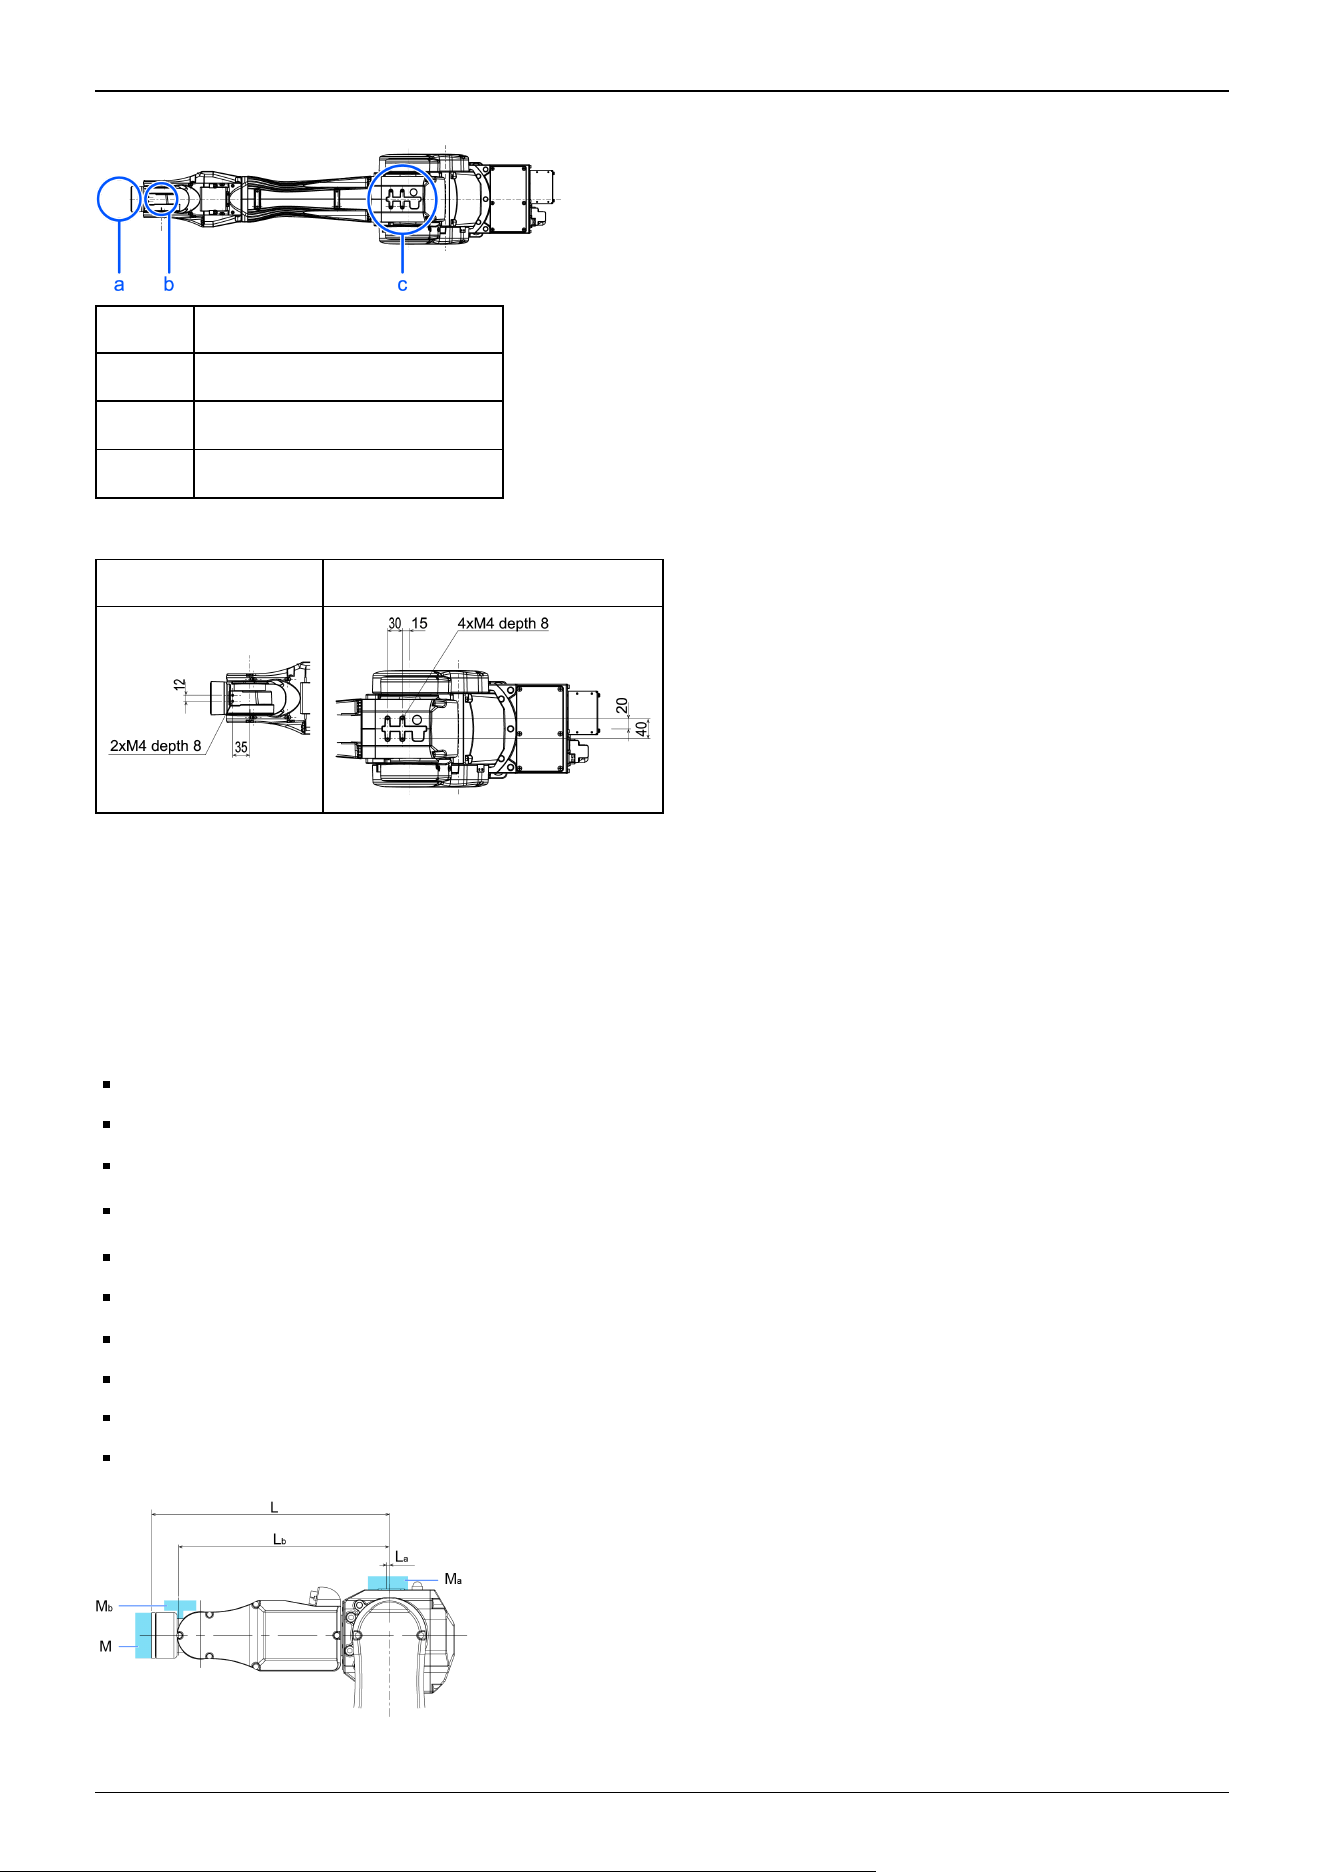
C8-C1401*** (C8XL)
Symbol Description
a Load on the fore end of Arm #6
b Arm #5 deck
c Arm #3 deck
Deck detailed (Units: mm)
Arm #5 deck Arm #3 deck
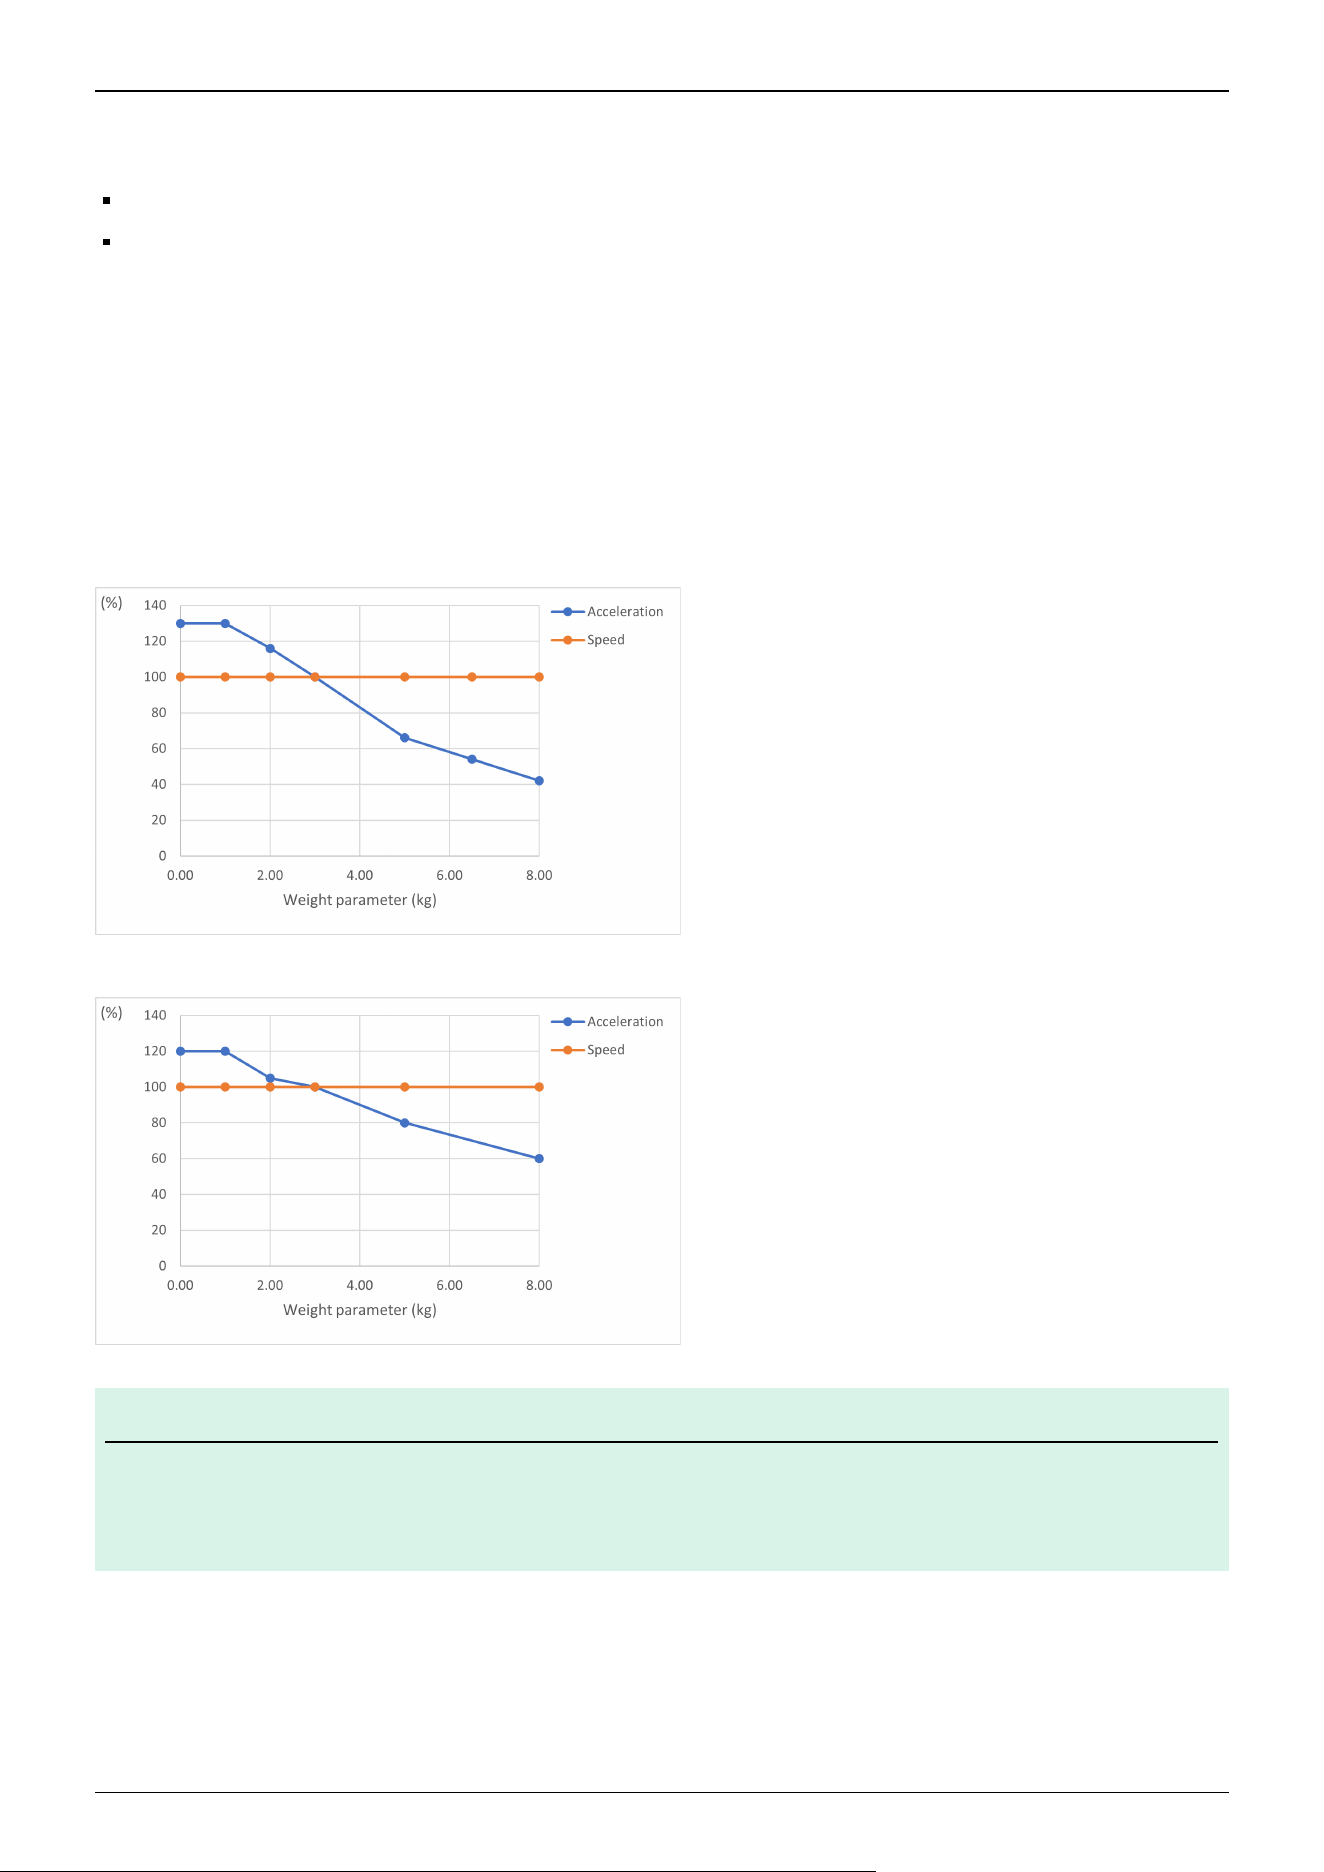
When you attach the equipment to the decks on the upper arm, convert its weight into equivalent weight assuming that the
equipment is attached to the end of the Arm #6. Then, this equivalent weight added to the load will be a Weight parameter.
Calculate the Weight parameter by using the formula below and enter the value.
Weight Parameter Formula
Weight parameter = M
w
+ W
a
+ W
b
M
w
: Payload on the fore end of Arm #6 (kg)
W
a
: Equivalent weight of the Arm #3 deck (kg)
W
b
: Equivalent weight of the Arm #5 deck (kg)
W
a
=M
a
(L
a
)
2
/(L)
2
W
b
=M
b
(L
b
)
2
/(L)
2
M
a
: Weight of the air valve on the Arm #3 deck (kg)
M
b
: Weight of the camera on the Arm #5 deck (kg)
L: Length of the upper arm (315 mm)
L
a
: Distance between the Joint #3 and the center of gravity of the air valve on the Arm #3 deck (mm)
L
b
: Distance between the Joint #3 and the center of gravity of the camera on the Arm #5 deck (mm)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
55
[Example] When the following loads apply to C8-C1401*** (C8XL) which fore end of the Arm #6 is 730 mm (L) away from
the Joint #3 and payload (M
w
) is 5 kg:
Load on the Arm #3 deck is 1.5 kg (M
a
). The deck is 0 mm (L
a
) away from the Joint #3.
Load on the Arm #5 deck is 1.0 kg (M
b
). The deck is 690 mm (L
b
) away from the Joint #3.
W
a
=1.5 × 0
2
/730
2
=0
W
b
=1.0 × 690
2
/730
2
=0.89 → 0.9 (round up)
M
w
+W
a
+W
b
=5+0+0.9=5.9
Enter "5.9" for the Weight parameter.
Automatic speed setting by Weight parameter
The percentage in the graph is based on the speed at rated weight (3 kg) as 100%.
C8-C901*** (C8L)
C8-C1401*** (C8XL)
KEY POINTS
Maximum AccelS setting value varies depending on Weight setting value. For details, refer to the following
section.
C8 Specifications
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
56
2.4.3.2 INERTIA Setting
Moment of Inertia and INERTIA Setting
The moment of inertia is a quantity that expresses how hard it is for an object to turn, and it is expressed in terms of values for
the moment of inertia, inertia, or GD
2
. When a hand or other object is attached to the Arm #6 for operation, the moment of
inertia of the load must be taken into consideration.
CAUTION
The moment of inertia of the load (hand + workpiece) must be 0.15 kg·m
2
or less.
The C8 Manipulators are not designed to work with a moment of inertia exceeding 0.15 kg·m
2
. Always set the
value corresponding to the moment of inertia. Setting a parameter value that is smaller than the actual
moment of inertia may cause errors or impact, may prevent the Manipulator from working at full functionality,
and may shorten the lifespan of mechanical parts.
The allowable moment of inertia of a load for C8 Manipulators is 0.03 kg·m
2
at the default rating and 0.15 kg·m
2
at the
maximum. Change the setting of the moment of inertia according to the inertia moment of the load using the INERTIA
command. After the setting is changed, the maximum acceleration/deceleration of Arm #6 that corresponds to the "Inertia"
value is corrected automatically.
Moment of Inertia of Load Attached to Arm #6
The moment of inertia of the load (hand + workpiece) attached to the Arm #6 can be set by the "Inertia" parameter in the
Inertia statement.
Go to [Tools] - [Robot Manager] - [Inertia] panel, and enter the value in [Inertia]. This can also be set using the Inertia
statement in [Command Window].
Eccentricity and INERTIA Setting
CAUTION
The eccentricity of the load (hand + workpiece) must be 300 mm or less. The C8 series Manipulators are not
designed to work with eccentricities exceeding 300 mm. Always set the value based on the eccentricity.
Setting the eccentricity parameter to a value smaller than the actual eccentricity may cause errors or impact
that not only impair full functionality but also shorten the life of the mechanical components.
The allowable eccentricity of load for C8 Manipulators is 50 mm at the default rating and 300 mm at the maximum. When the
load eccentricity exceeds the rating, change the setting for the eccentricity parameter in Inertia statement. After the setting is
changed, the maximum acceleration/deceleration of the Manipulator that corresponds to the "Eccentricity" is corrected
automatically.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
57
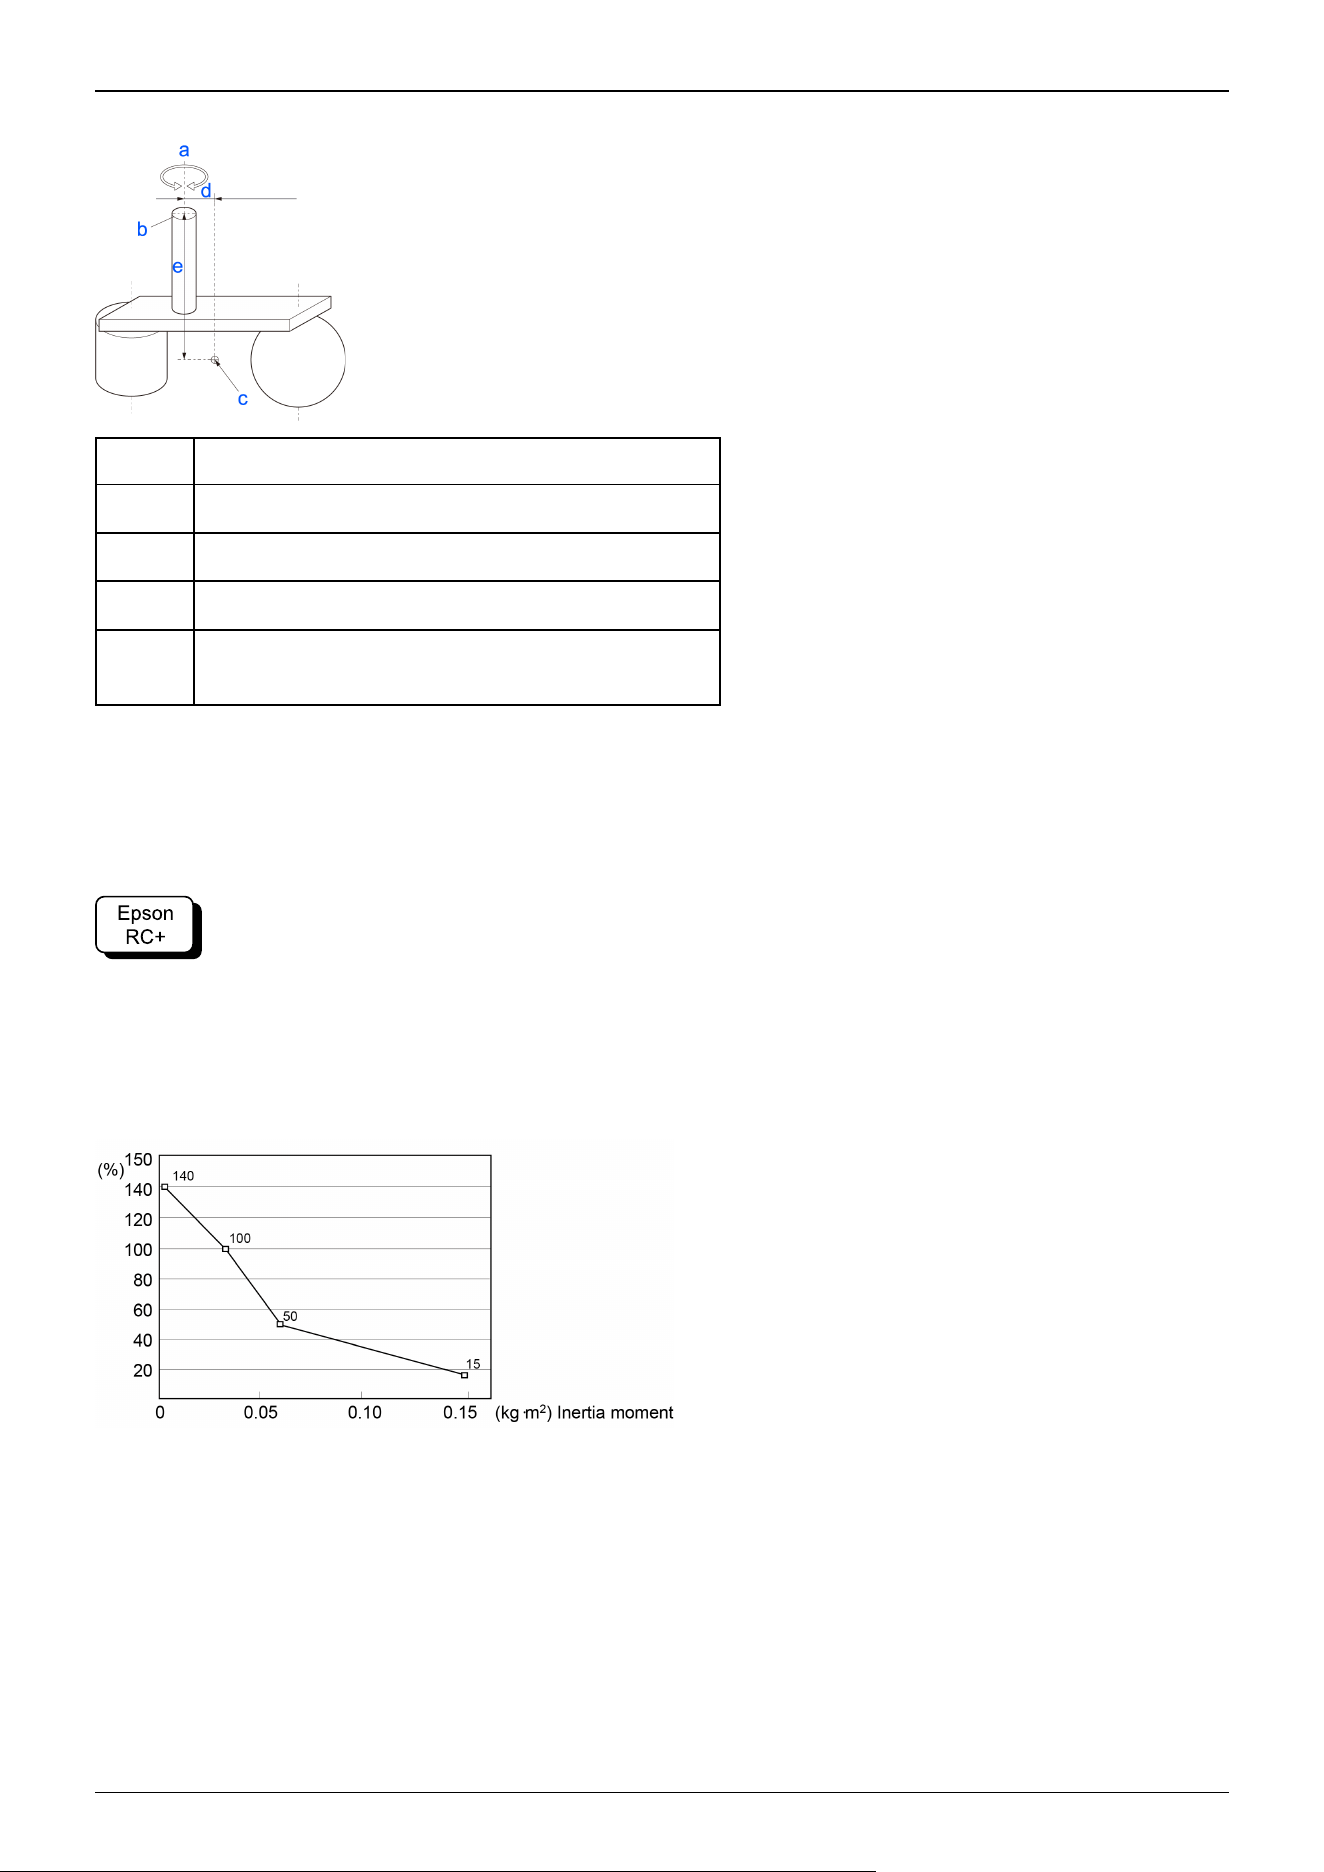
Eccentricity
Symbol Description
a Rotation axis
b Flange
c Load center of gravity position
d, e
Eccentricity (300 mm or less)
To set the parameter, enter the larger value of "d" or "e".
Eccentricity of Load Attached to Arm #6
The eccentricity of the load (hand + workpiece) attached to the Arm #6 can be set by the "Eccentricity" parameter in the Inertia
statement.
Enter the larger value of either "d" or "e" in the figure above to [Eccentricity].
Go to [Tools] - [Robot Manager] - [Inertia] panel, and enter the value in [Eccentricity]. This can also be set using the Inertia
statement in [Command Window].
Automatic Acceleration/Deceleration Correction at INERTIA (Eccentricity) Setting
Automatic setting by inertia moment setting (common to C8 series)
* The percentages on the graph are ratios based on 100% as the acceleration/deceleration at the rated (0.03 kg·m
2
) setting.
Automatic setting by eccentricity setting (common to C8 series)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
58
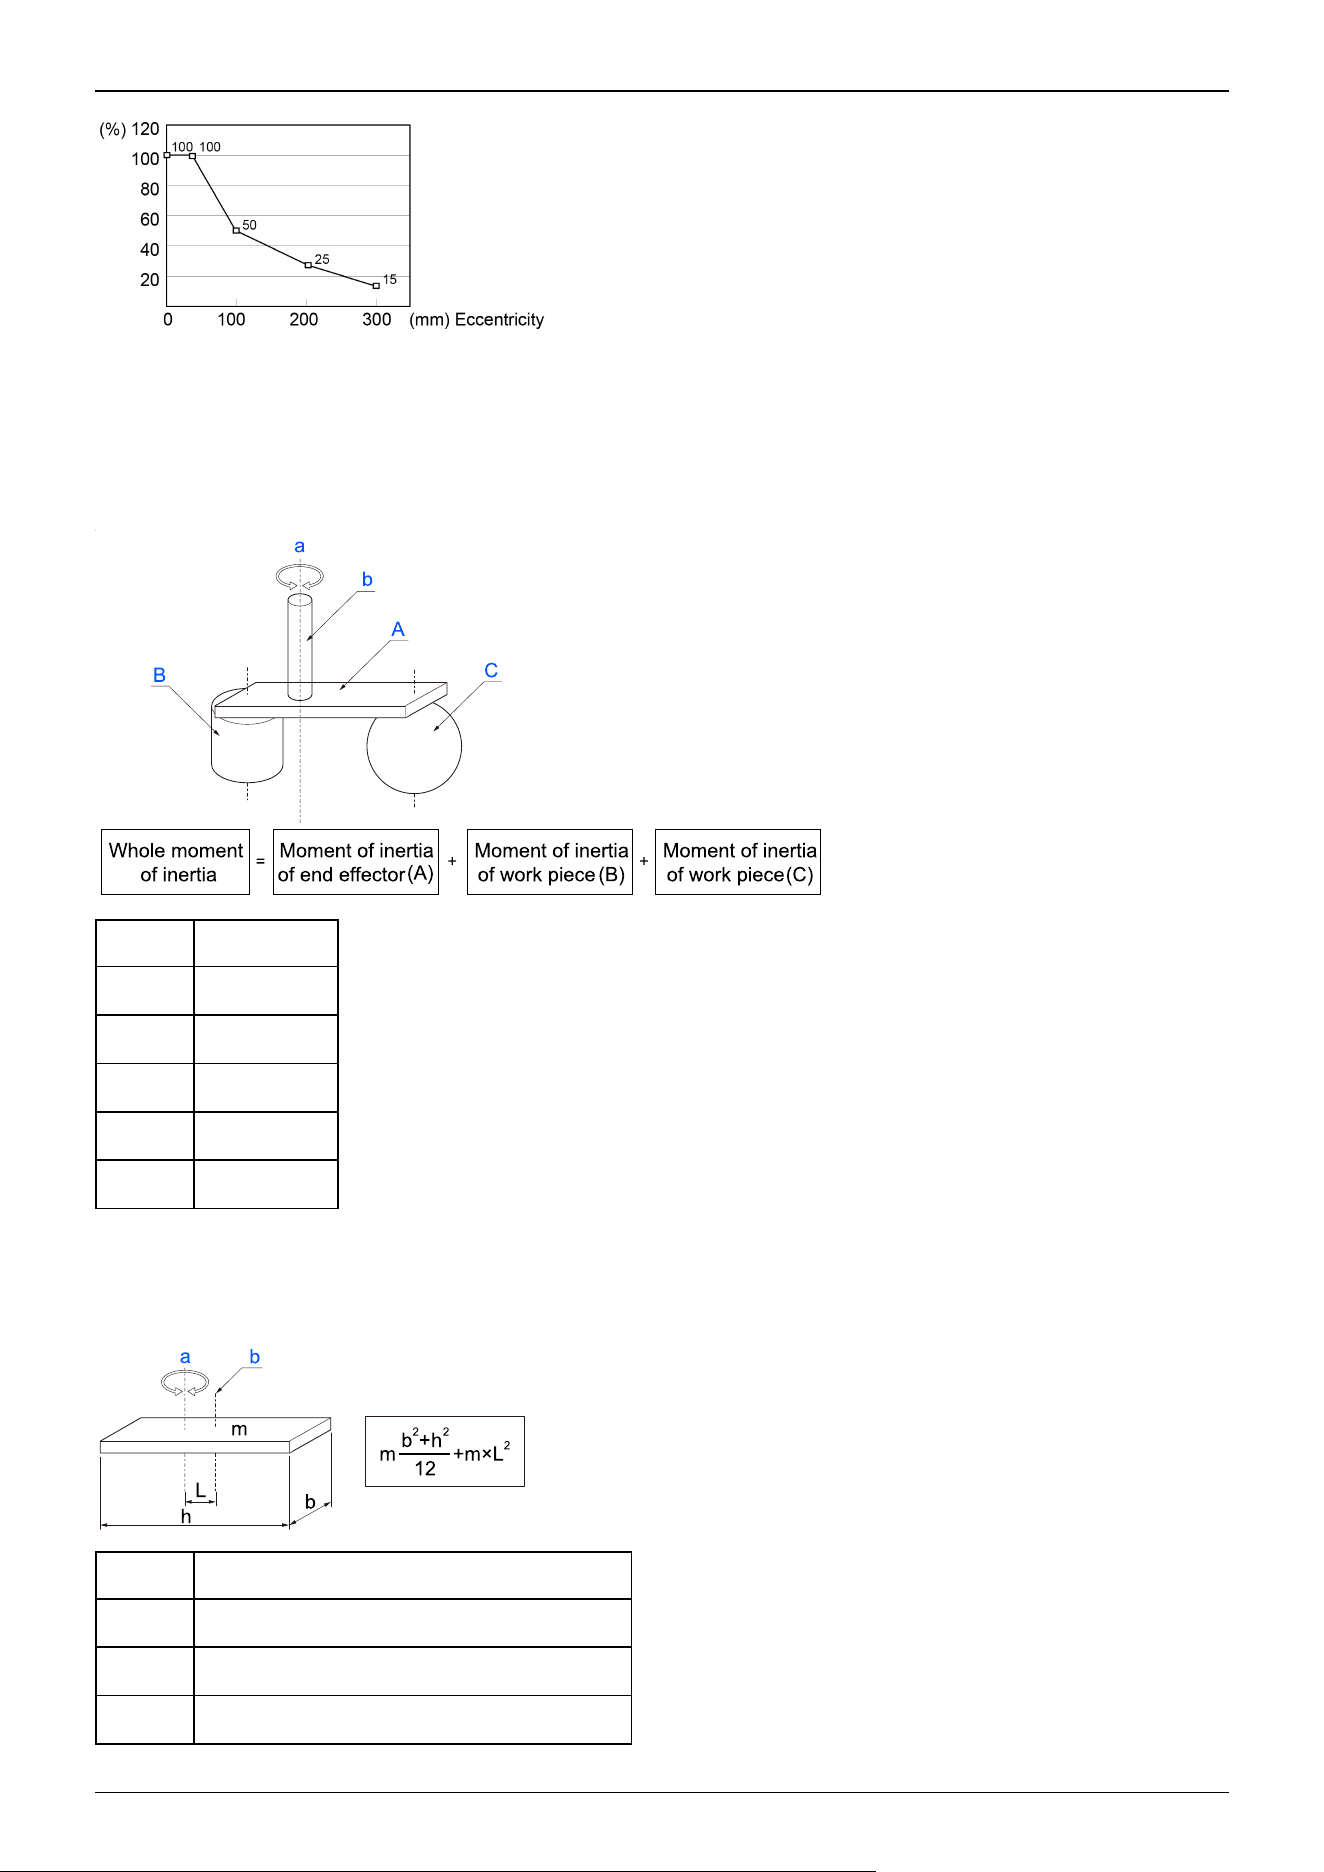
* The percentages on the graph are ratios based on 100% as the acceleration/deceleration at the rated (50 mm) setting.
Calculating the Moment of Inertia
An example of calculating the moment of inertia of a load (hand holding a workpiece) is shown below.
The moment of inertia of the entire load is calculated by the sum of (A), (B), and (C).
Symbol Description
a Rotation axis
b Shaft
A Hand
B Workpiece
C Workpiece
The methods for calculating the moment of inertia for (A), (B), and (C) are shown below. Use the moment of inertia of these
basic shapes as a reference to find the moment of inertia of the entire load.
(A) Moment of inertia of a rectangular parallelepiped
Symbol Description
a Rotation axis
b Center of gravity of rectangular parallelepiped
m Weight
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
59
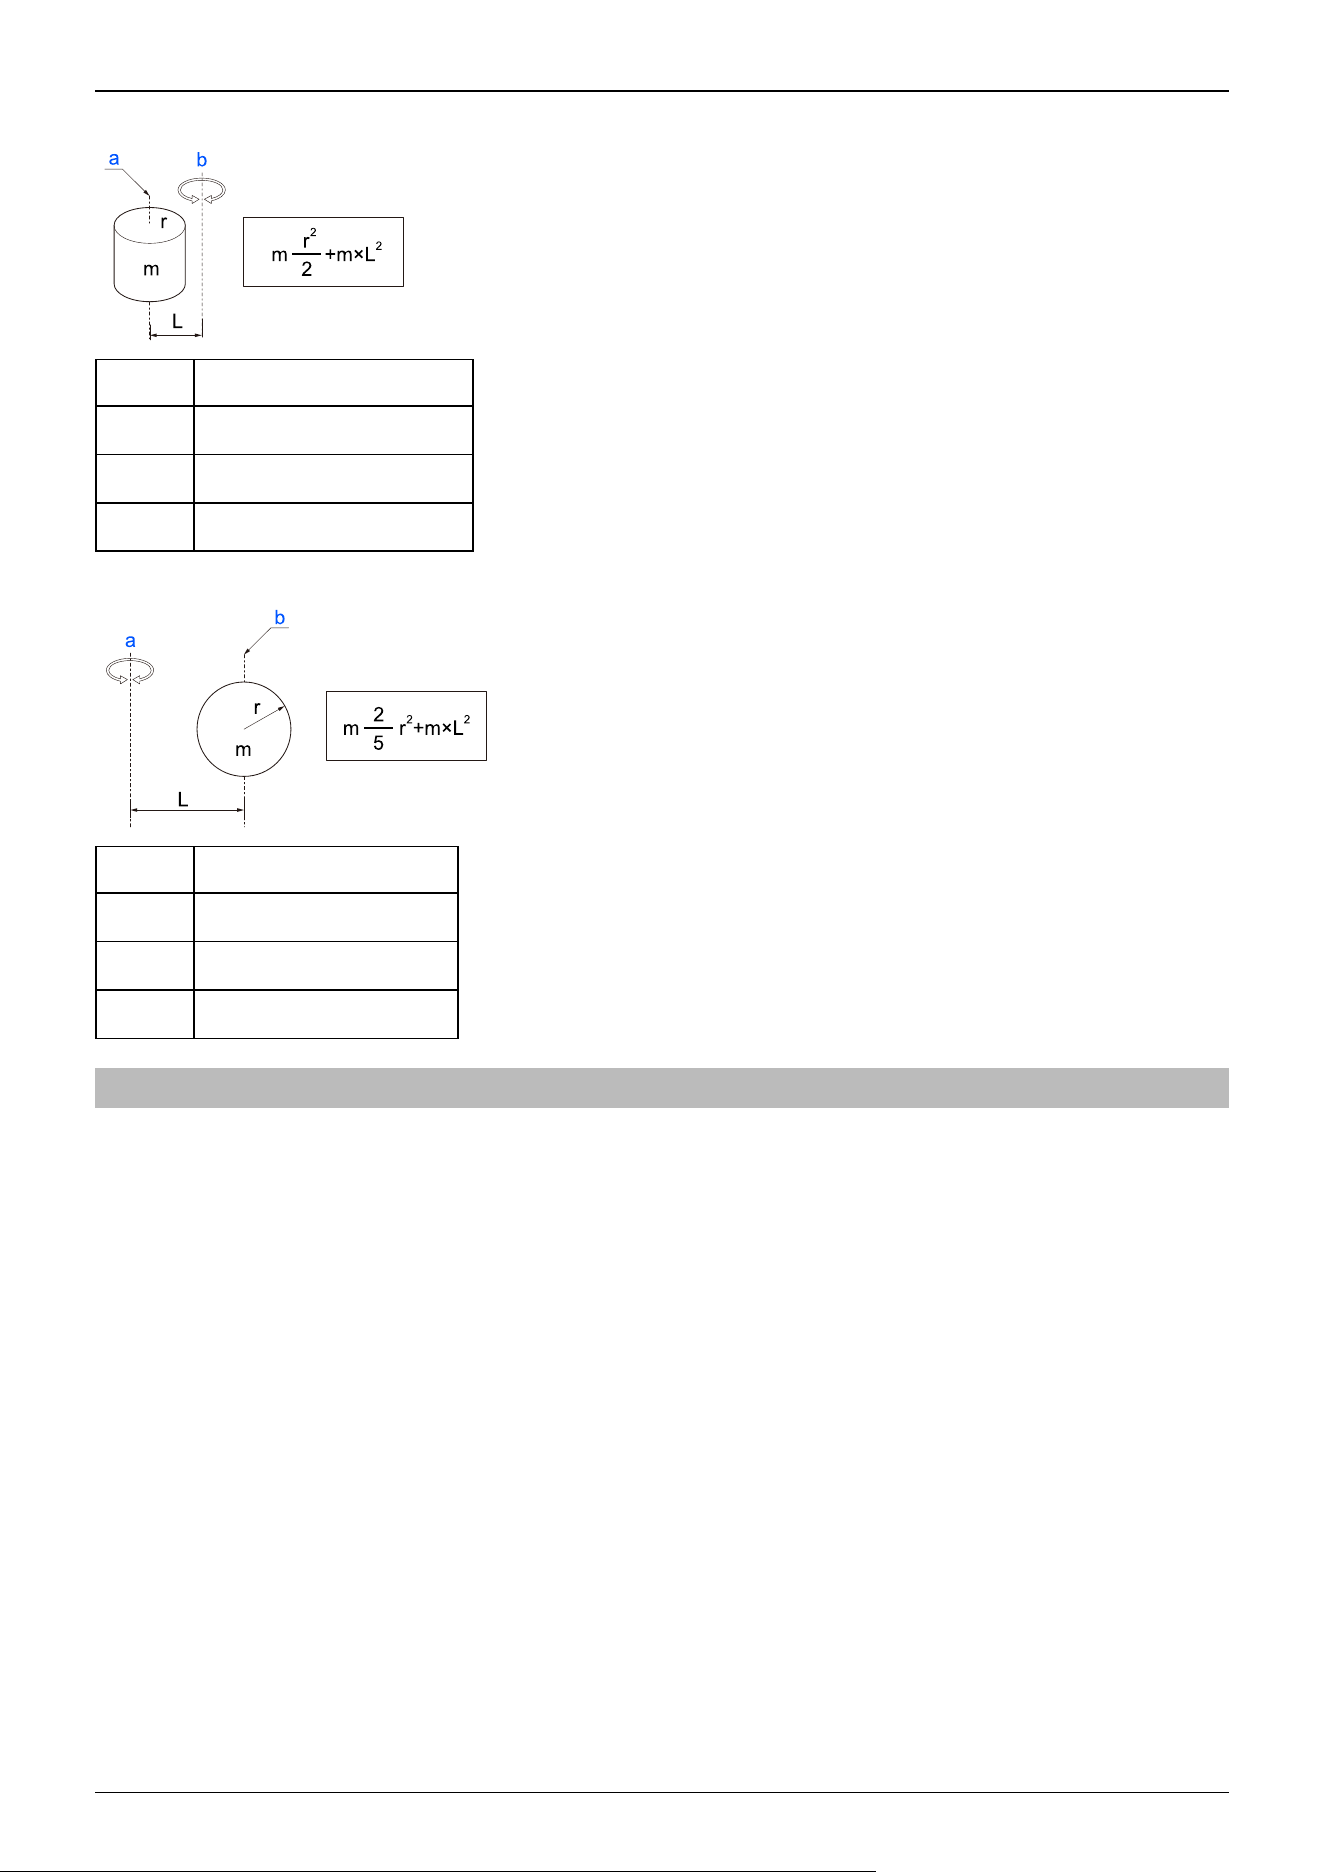
(B) Moment of inertia of a cylinder
Symbol Description
a Center of gravity of cylinder
b Rotation axis
m Weight
(C) Moment of inertia of a sphere
Symbol Description
a Rotation axis
b Center of gravity of sphere
m Weight
2.4.4 Safety Information for Auto Acceleration
The speed and acceleration/deceleration of the Manipulator motion are automatically optimized according to the values of
WEIGHT and INERTIA and the Manipulator’s postures.
WEIGHT Setting
The speed and acceleration/deceleration of the Manipulator are controlled according to the load weight set by the WEIGHT
command. The more the load weight increases, the more the speed and acceleration/deceleration are reduced to prevent
residual vibration.
INERTIA Setting
The acceleration/deceleration of Arm #6 are controlled according to the inertia moment set by the INERTIA command. The
acceleration/deceleration of the whole Manipulator are controlled according to the eccentricity set by the INERTIA command.
The more the inertia moment and eccentricity of the load increase, the more the acceleration/ deceleration are reduced.
Auto Acceleration/Deceleration According to Manipulator’s Posture
The acceleration/deceleration are controlled according to the Manipulator’s posture. When the Manipulator extends its arms or
when the movement of the Manipulator produces vibration frequently, the acceleration/deceleration are reduced.
Set appropriate values for WEIGHT and INERTIA so that the Manipulator operation is optimized.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
60
2.5 Work Envelope
WARNING
Do not operate the Manipulator with the mechanical stop removed. Removing the mechanical stop is
extremely dangerous because the Manipulator may move to a position outside its normal work envelope.
CAUTION
When restricting the work envelope for safety reasons, be sure to make settings using both the pulse range
and mechanical stop.
The work envelope is preset at the factory as explained in the following section. This is the maximum work envelope of the
Manipulator.
Standard Work Envelope
The work envelope can be set by one of the following three methods.
1. Setting by pulse range (for each joint)
2. Setting by mechanical stops
3. Setting the rectangular range in the XY coordinate system of the Manipulator
To limit the work envelope for layout efficiency or safety reasons, make the settings as explained in the following sections.
Work Envelope Setting by Pulse Range (for Each Joint)
Setting the Work Envelope by Mechanical Stops
Restriction of Manipulator Operation by Joint Angle Combination
Coordinate System
2.5.1 Work Envelope Setting by Pulse Range (for Each Joint)
Pulses are the basic unit of Manipulator motion. The motion range (work envelope) of the Manipulator is set by the pulse
lower limit value and pulse upper limit value (pulse range) for each joint. Pulse values are read from the encoder output of the
servomotor.
Be sure to set the pulse range within the mechanical stop range.
KEY POINTS
The Arm #1 and #4 do not have a mechanical stop.
Once the Manipulator receives a motion command, it checks whether the target position specified by the
command is within the pulse range before operating. If the target position is outside of the pulse range that
was set, an error occurs and the Manipulator does not move.
Pulse range
Work Envelope
Mechanical
Stop
Mechanical
Stop
Rectangular range setting
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
61
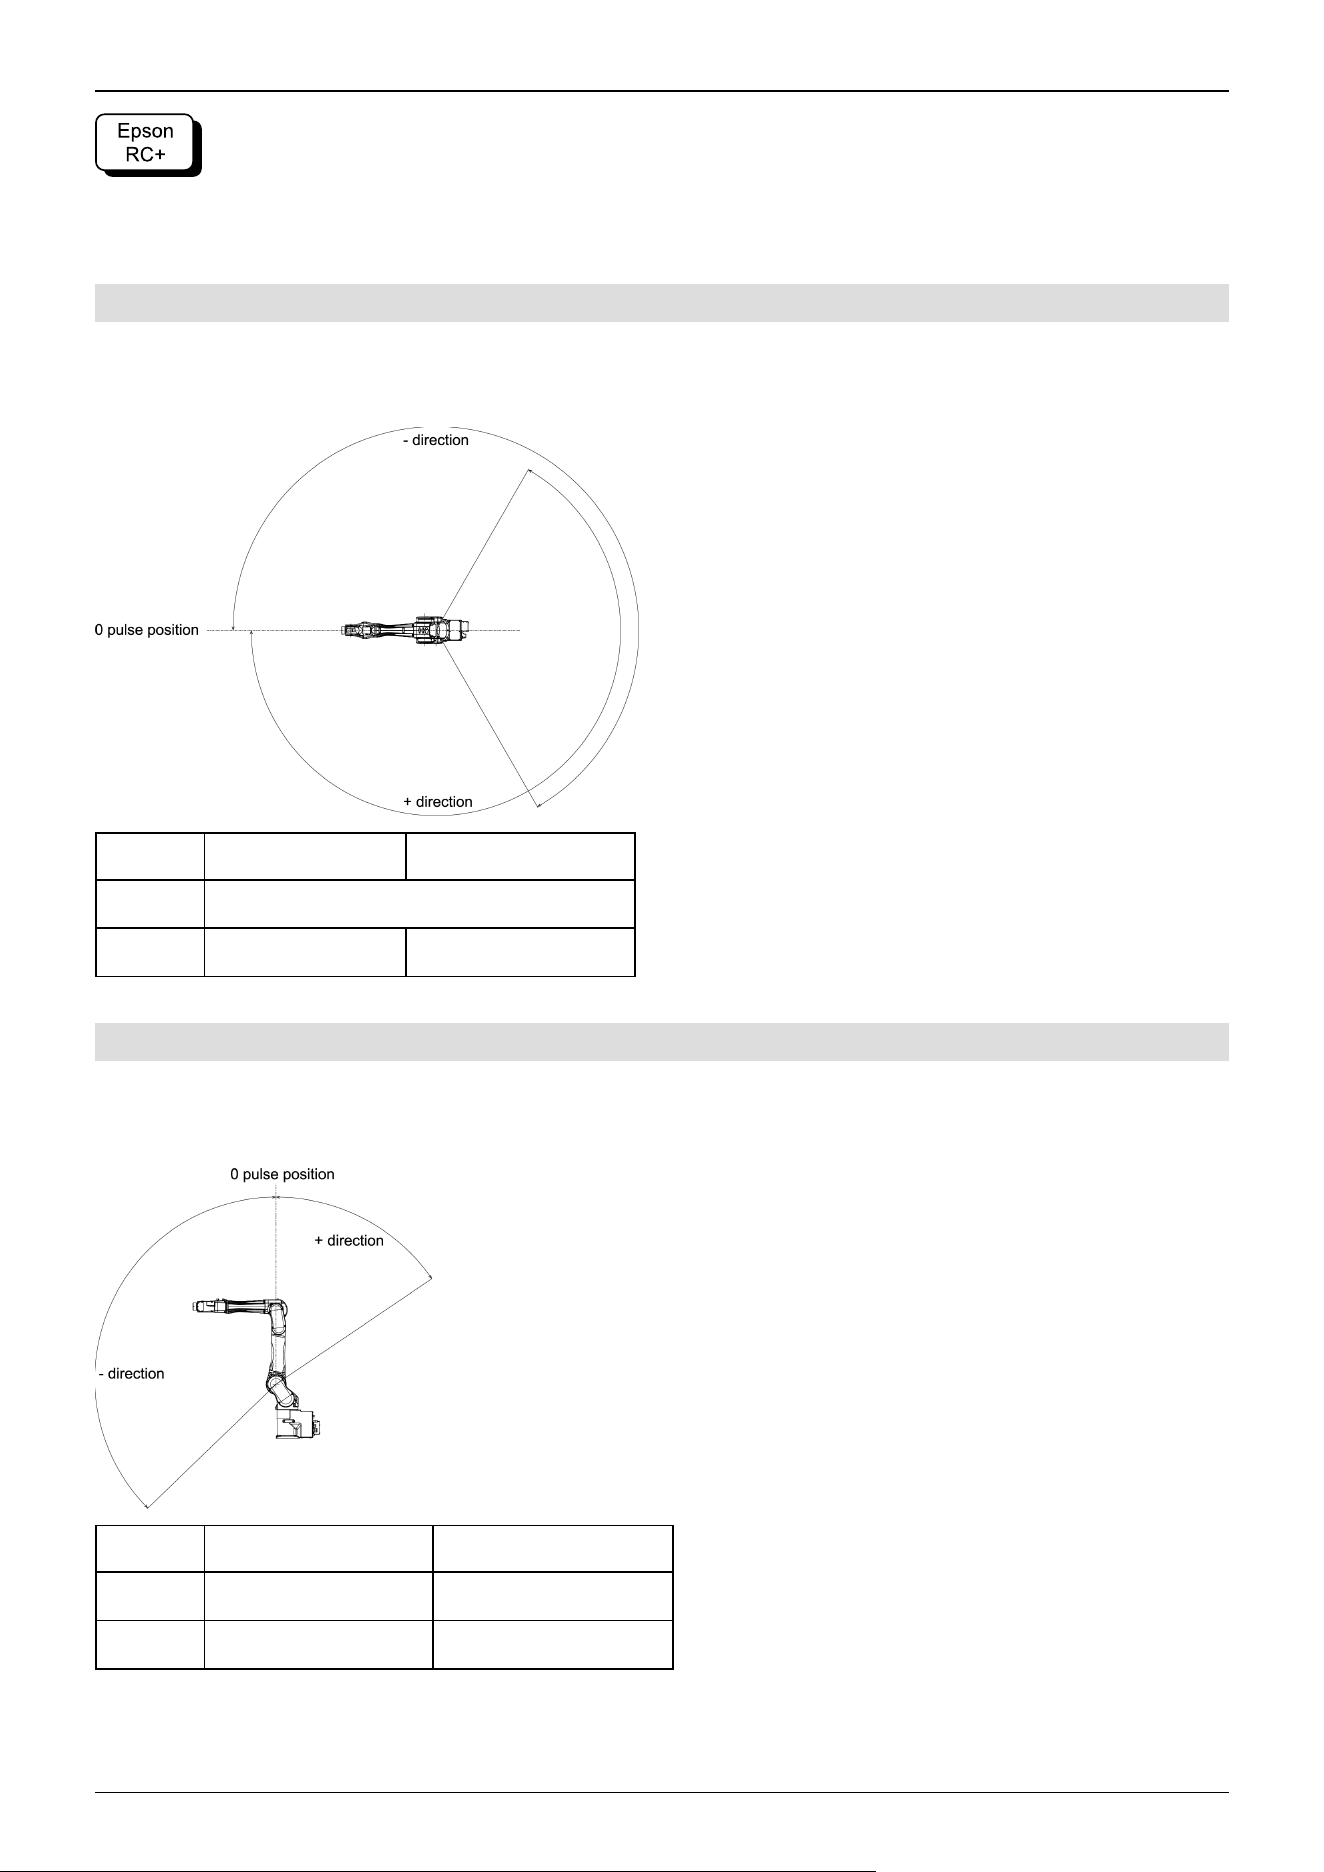
Go to [Tools] - [Robot Manager] - [Range] panel, and make the setting. This can also be set using the Range statement in
[Command Window].
2.5.1.1 Joint #1 Maximum Pulse Range
With the 0 pulse as a starting point, the counterclockwise pulse value is defined as positive (+), and the clockwise pulse value
is defined as negative (-).
C8-C901*** (C8L) C8-C1401*** (C8XL)
Angle (°) ±240
Pulse ±10695600 ±15736800
2.5.1.2 Joint #2 Maximum Pulse Range
With the 0 pulse as a starting point, the clockwise pulse value is defined as positive (+), and the counterclockwise pulse value
is defined as negative (-).
C8-C901*** (C8L) C8-C1401*** (C8XL)
Angle (°) -158 to +65 -135 to +55
Pulse -6903178 to +2839915 -10616940 to +4325420
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
62
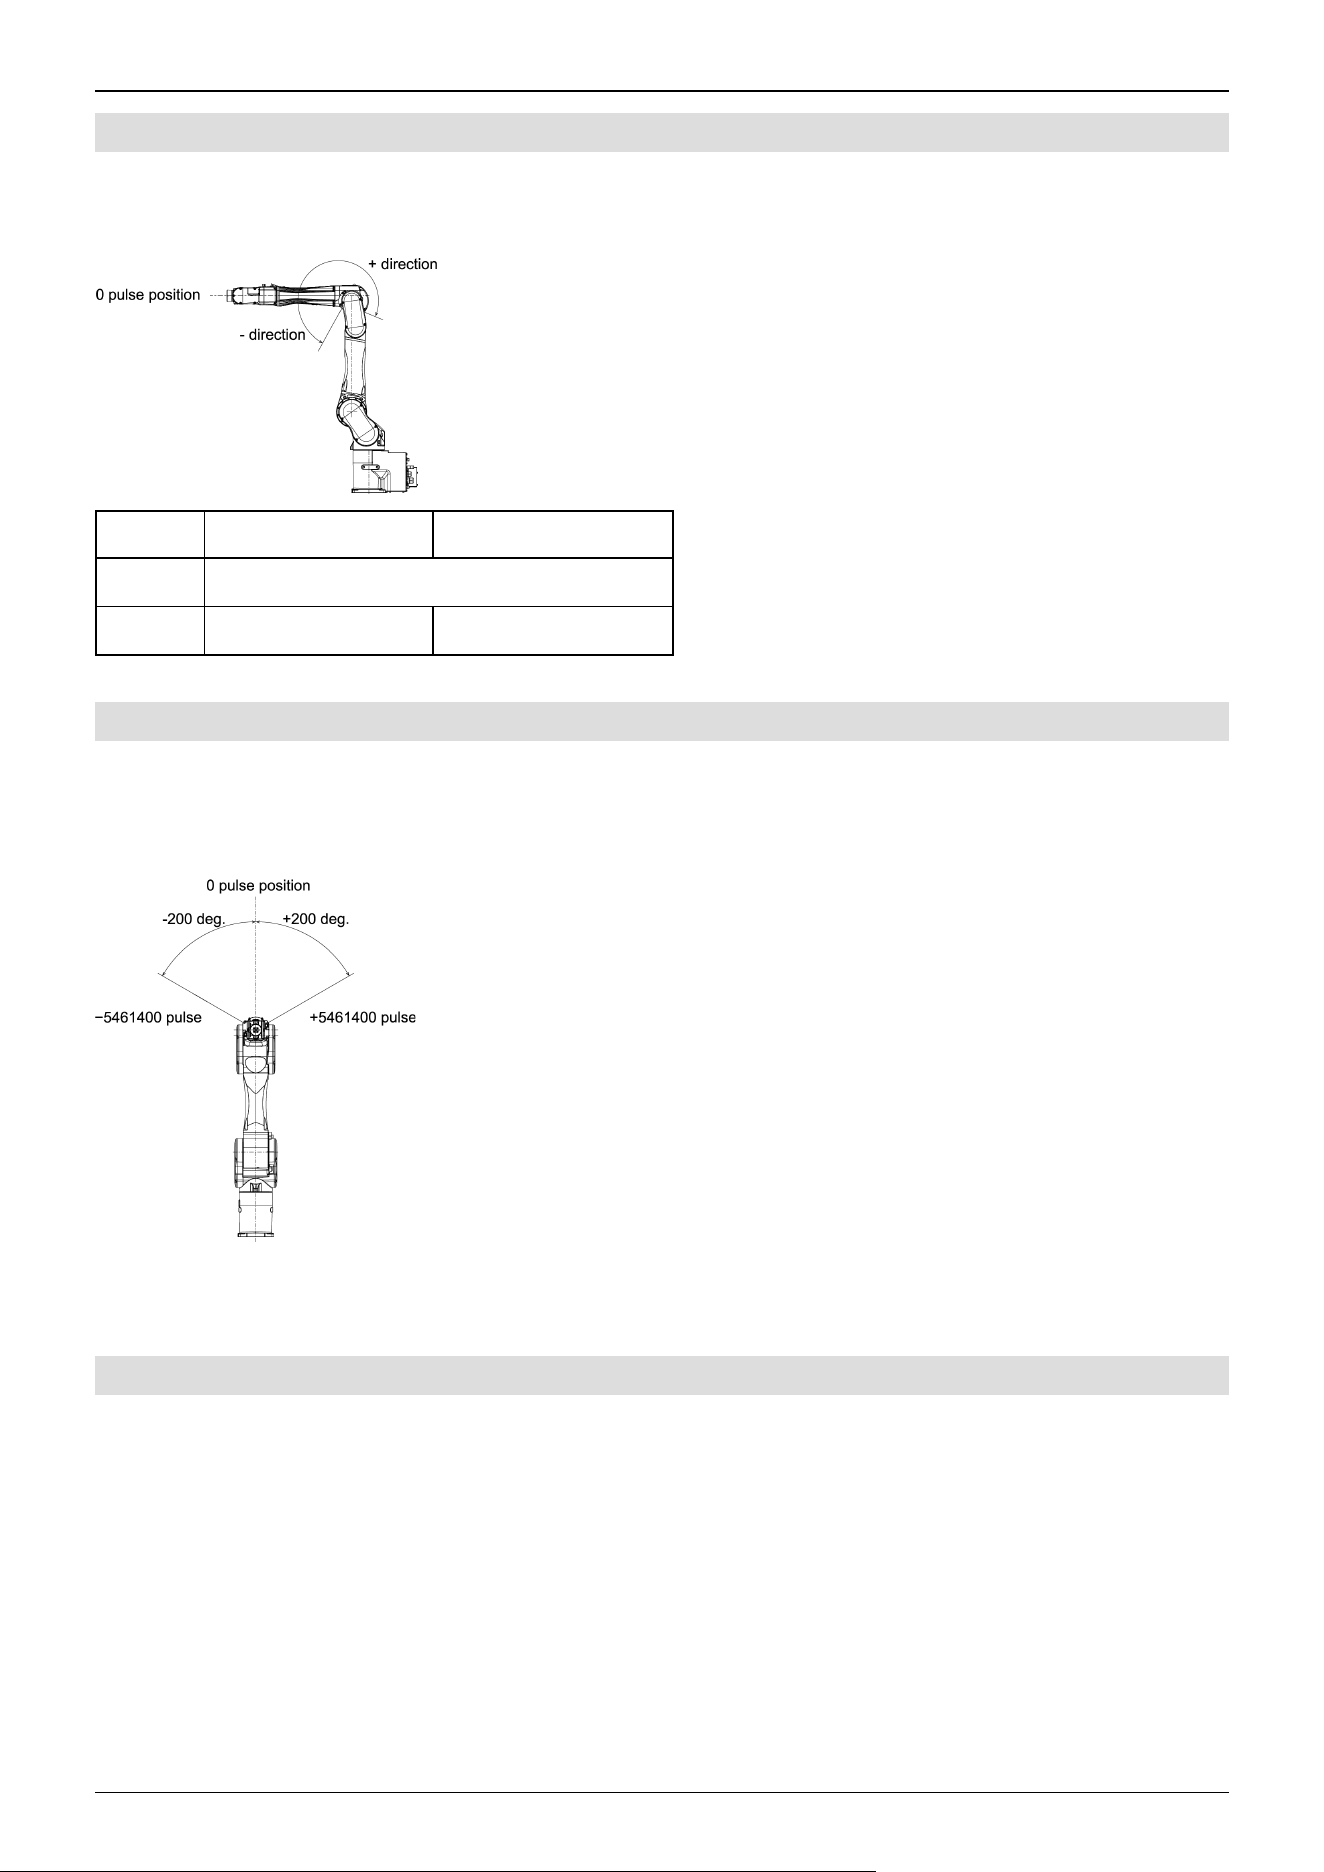
2.5.1.3 Joint #3 Maximum Pulse Range
With the 0 pulse as a starting point, the clockwise pulse value is defined as positive (+), and the counterclockwise pulse value
is defined as negative (-).
C8-C901*** (C8L) C8-C1401*** (C8XL)
Angle (°) -61 to +202
Pulse -2220949 to +7354618 -3997696 to +13238272
2.5.1.4 Joint #4 Maximum Pulse Range
From the angle of arm end, with the 0 pulse as a starting point, the clockwise pulse value is defined as positive (+), and the
counterclockwise pulse value is defined as negative (-). The max. pulse range of the Arm #4 is common to C8 series
Manipulators.
(deg.=°)
2.5.1.5 Joint #5 Maximum Pulse Range
With the 0 pulse as a starting point, the clockwise pulse value is defined as positive (+), and the counterclockwise pulse value
is defined as negative (-). The max. pulse range of the Arm #5 is common to C8 series Manipulators.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
63
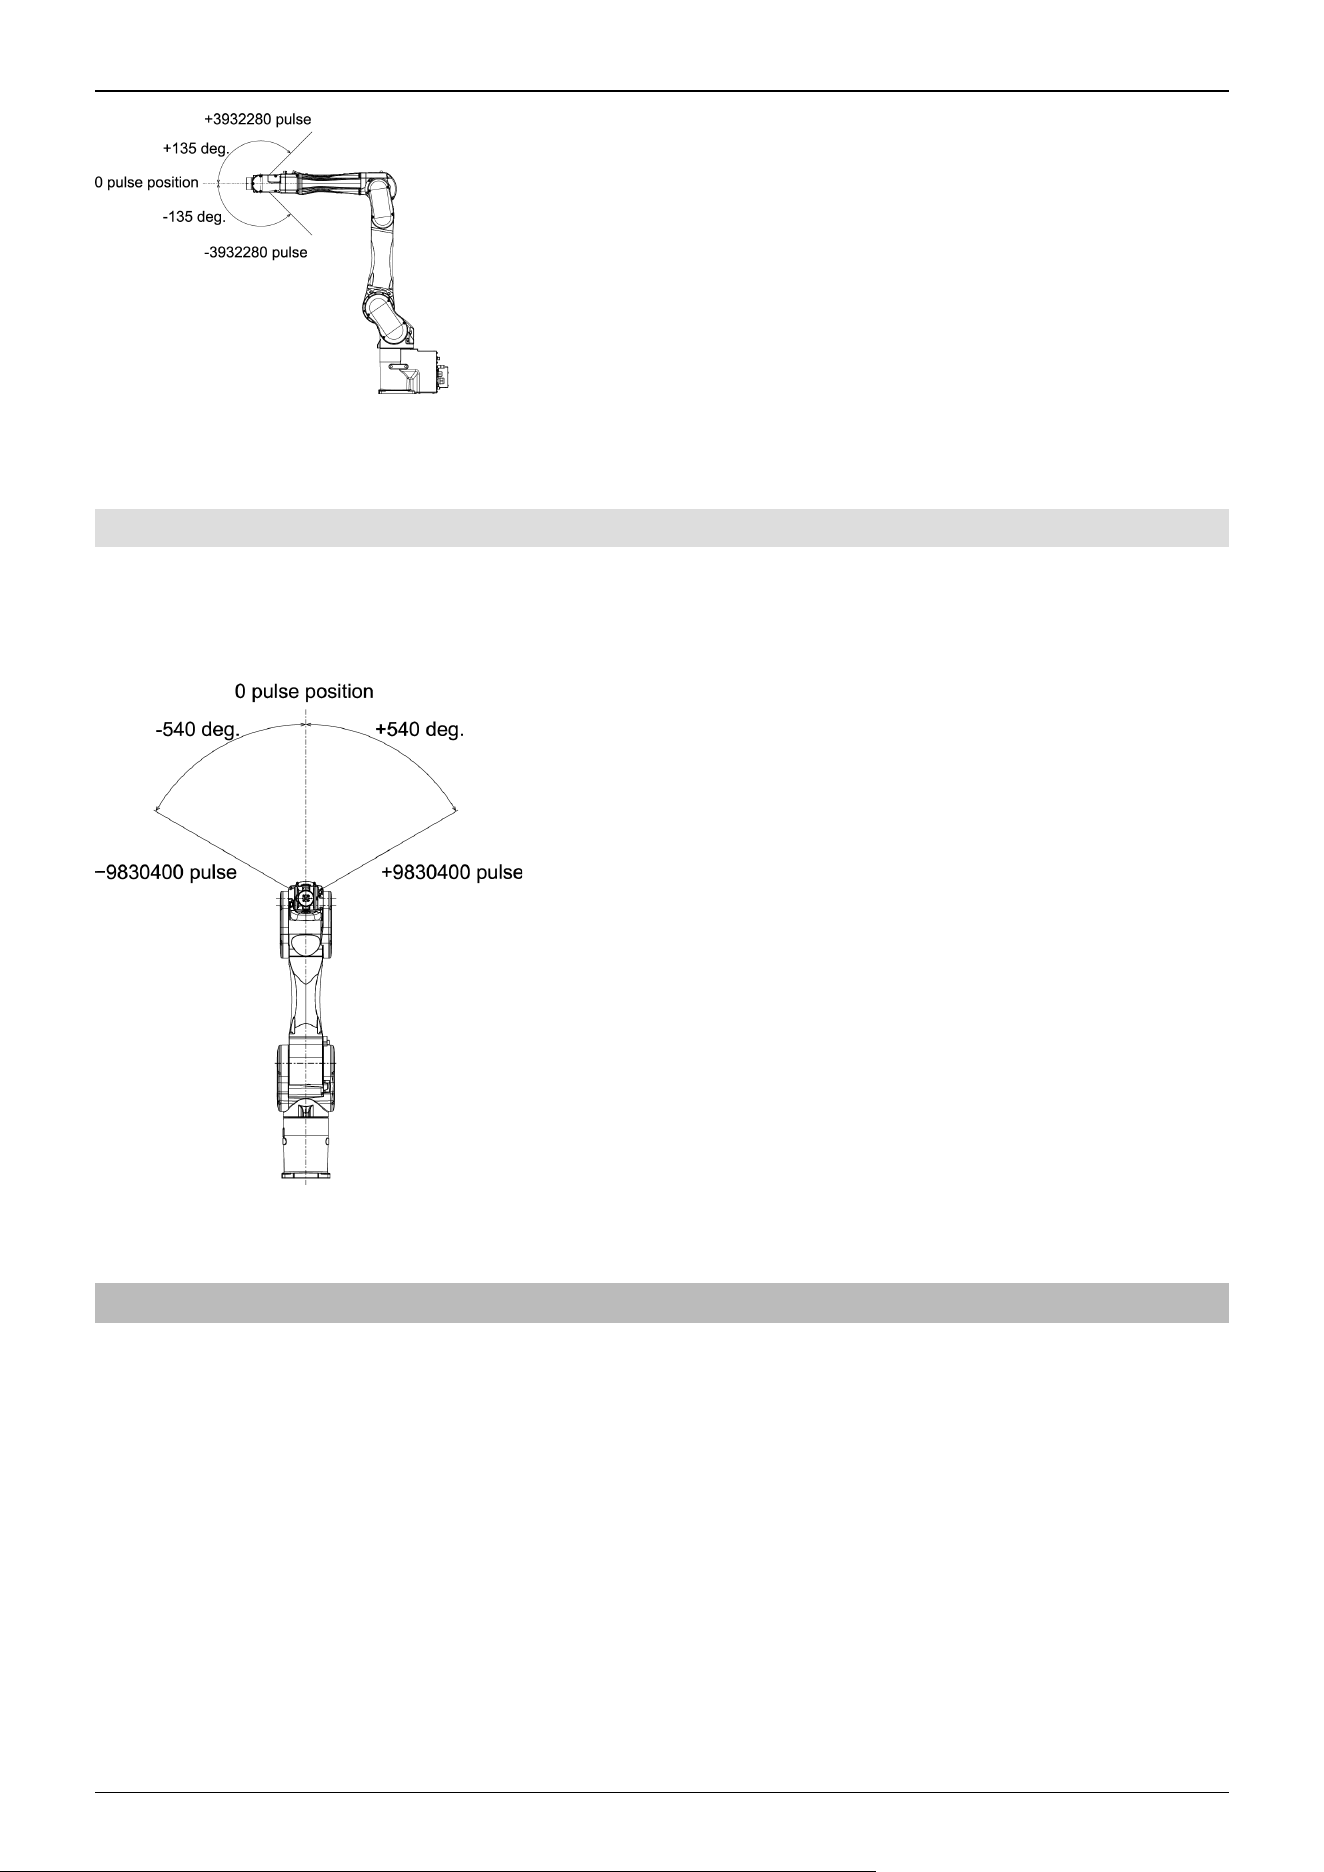
(deg.=°)
2.5.1.6 Joint #6 Maximum Pulse Range
From the angle of arm end, with the 0 pulse as a starting point, the clockwise pulse value is defined as positive (+), and the
counterclockwise pulse value is defined as negative (-). The max. pulse range of the Arm #6 is common to C8 series
Manipulators.
(deg.=°)
2.5.2 Setting the Work Envelope by Mechanical Stops
Using the variable mechanical stops physically limits the absolute area that the Manipulator can move.
Before starting any work, be sure to turn off the Manipulator.
Use bolts conforming to the specified length and surface processing (ex: nickel plating) with high corrosion resistance.
Specify the pulse range again after changing the position of the mechanical stop.
For details on the pulse range setting, refer to the following section.
Work Envelope Setting by Pulse Range (for Each Joint)
Be sure to set the pulse range inside the positions of the mechanical stop range.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
64
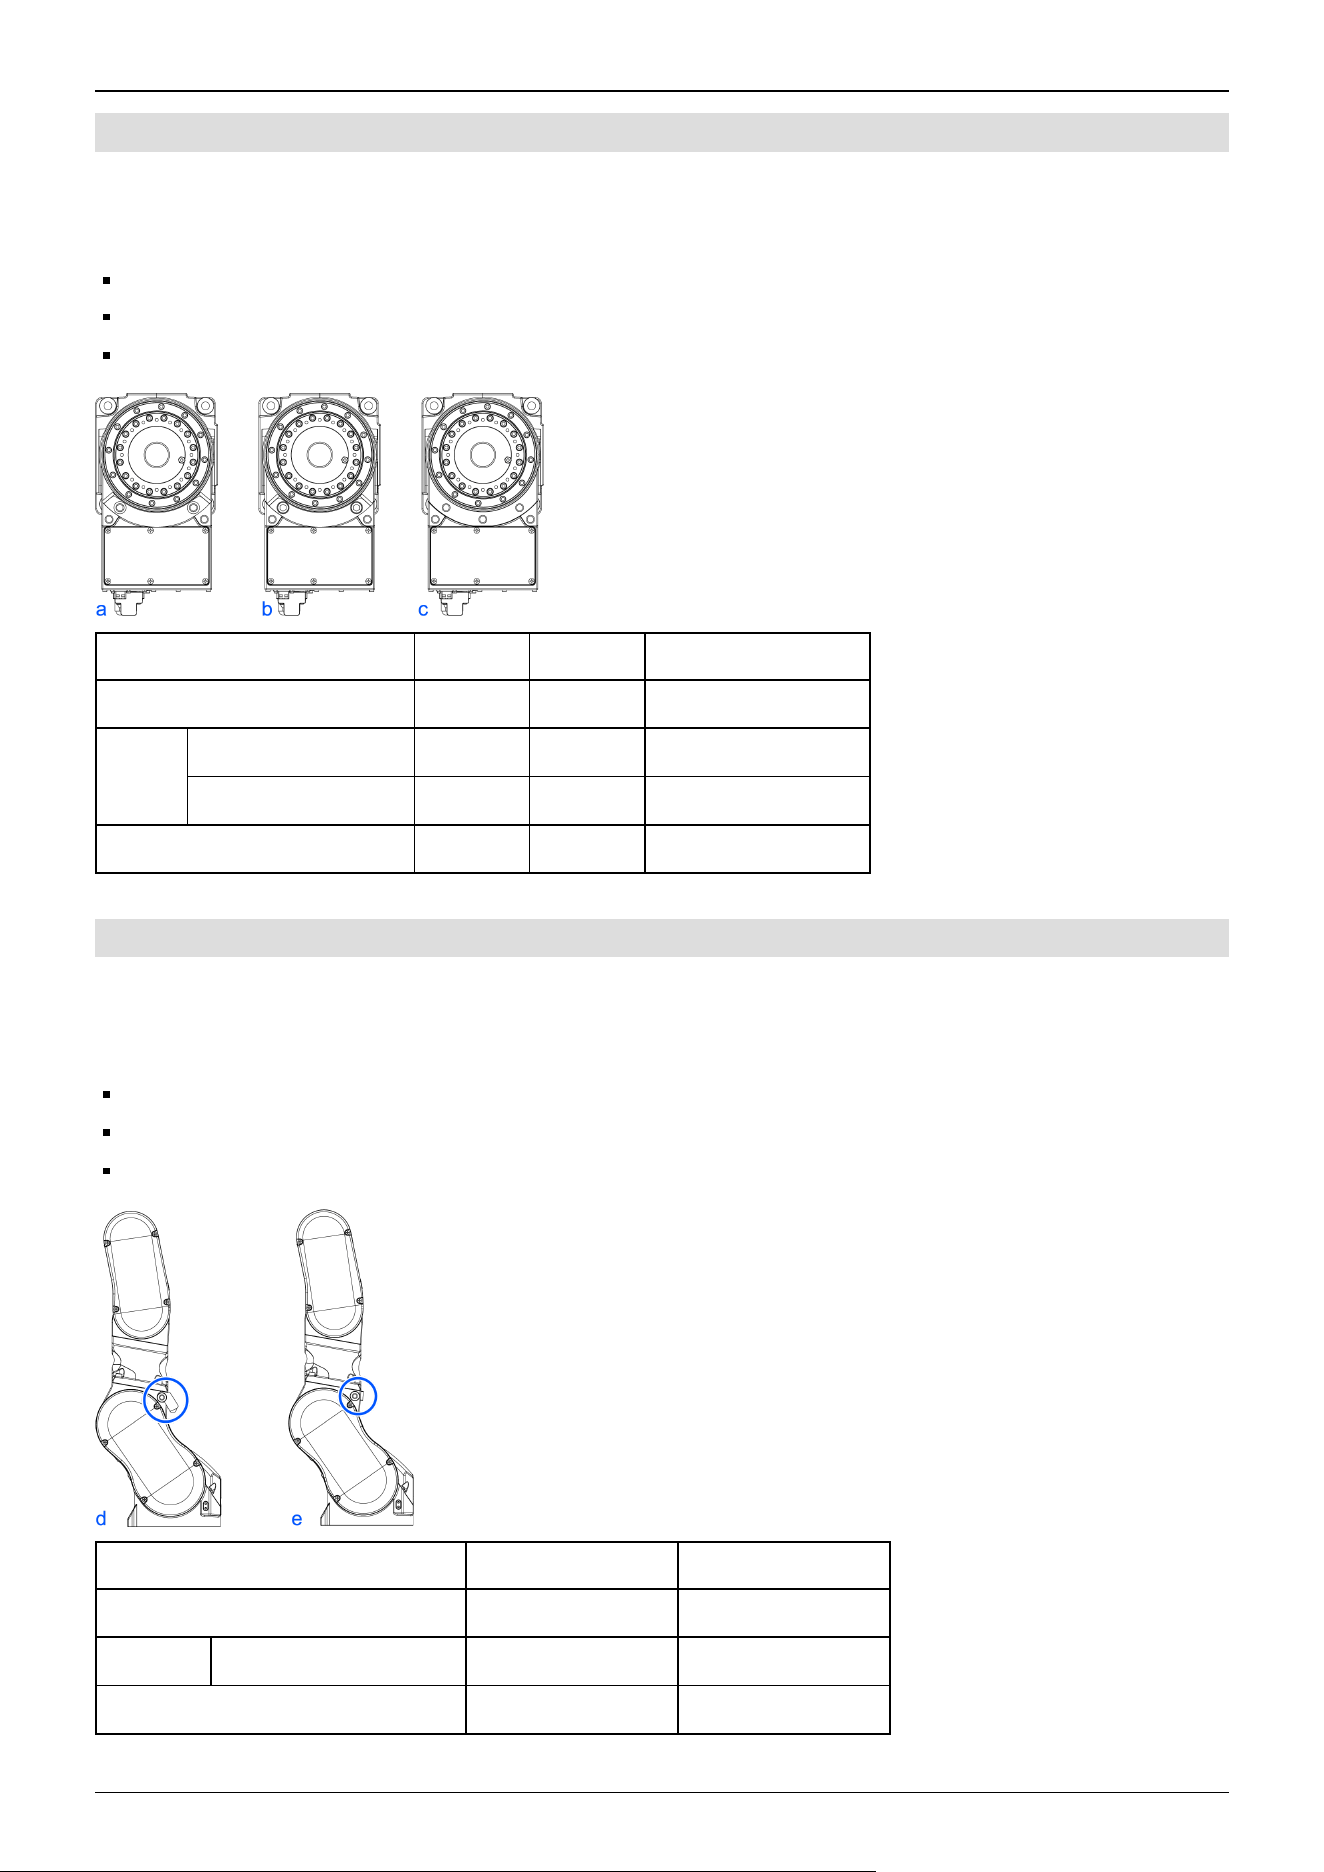
2.5.2.1 Setting the Joint #1 Work Envelope
Install variable mechanical stop (J1) in the threaded holes corresponding to the angles to be set.
Normally a mechanical stop is not equipped.
Hexagon socket head cap bolt: M12 × 30 × 2 bolts
Strength: Compliant with ISO 898-1 property class: 10.9 or 12.9
Tightening torque: 42.0 ± 2.1 N·m (428 ± 21 kgf·cm)
a b c
Angle (°) ±110 ±105 ±240
Pulse
C8-C901*** (C8L) ±4902150 ±4679271 ±10695600
C8-C1401*** (C8XL) ±7212700 ±6884840 ±15736800
Variable Mechanical Stop (J1) Applied Applied Not applied (standard)
2.5.2.2 Setting the Joint #2 Work Envelope
C8-C901*** (C8L)
Remove the mechanical stop installed as standard and install the variable mechanical stop (C8/C8L_J2). (Joint #2 standard
work envelope -158 to +65°)
Hexagon socket head cap bolt: M10 × 35 × 1 bolts
Strength: Compliant with ISO 898-1 property class: 10.9 or 12.9
Tightening torque: 32.0 ± 1.6 N·m (326 ± 16 kgf·cm)
d e
Angle (°) -158, +30 -158, +65
Pulse C8-C901*** (C8L) -6903178, +1310730 -6903178, +2839915
Variable mechanical stop (C8/C8L_J2) Applied Applied (standard)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
65
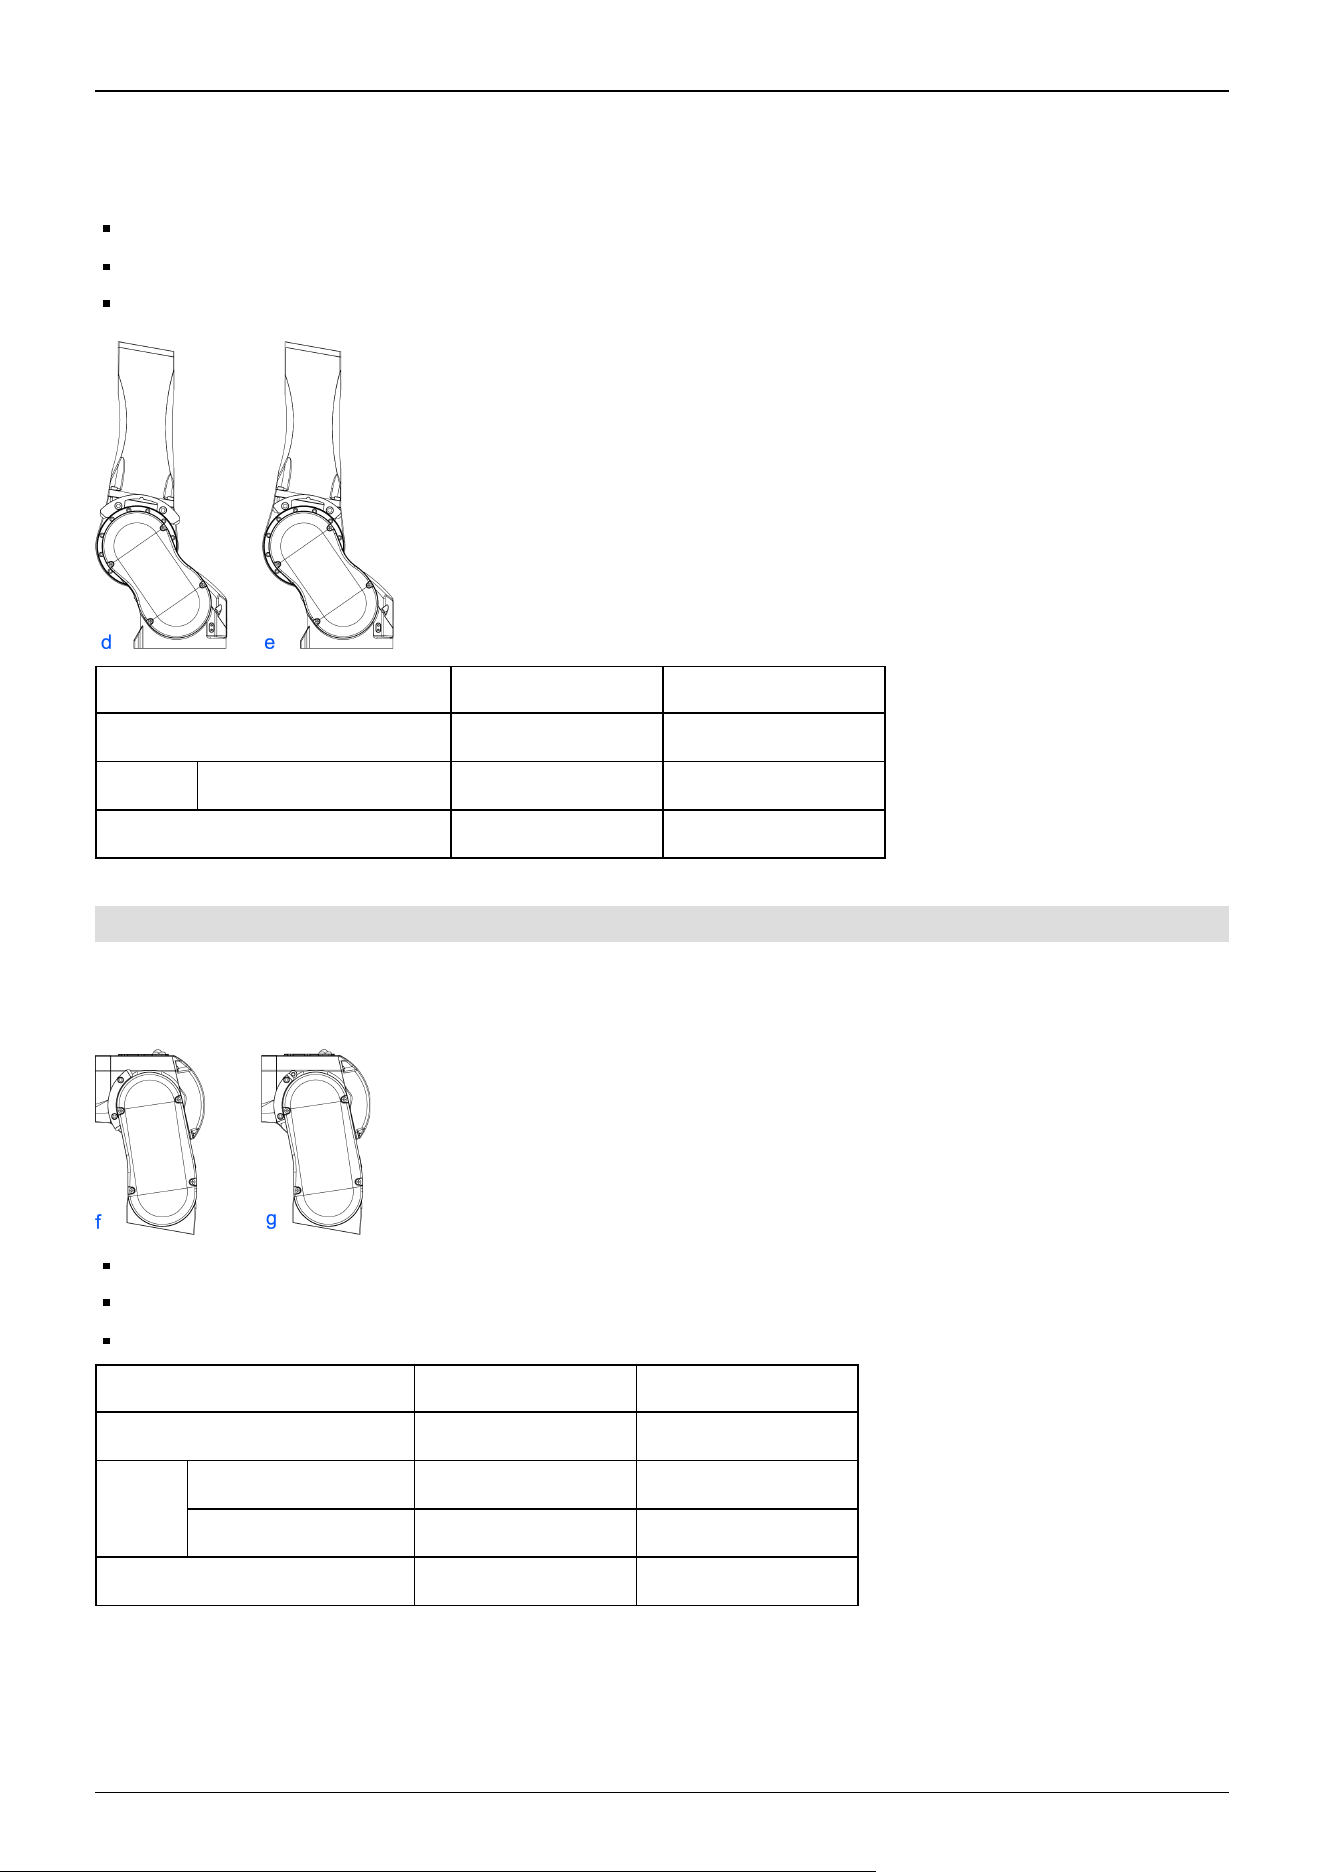
C8-C1401*** (C8XL)
Remove the mechanical stop installed as standard and install the variable mechanical stop (C8XL_J2). (Joint #2 standard work
envelope -135 to +55°)
Hexagon socket head cap bolt: M10 × 35 × 2 bolts
Strength: Compliant with ISO 898-1 property class: 10.9 or 12.9
Tightening torque: 32.0 ± 1.6 N·m (326 ± 16 kgf·cm)
d e
Angle (°) -125, +45 -135, +55
Pulse C8-C1401*** (C8XL) -9830500, +3538980 -10616940, +4325420
Variable mechanical stop (C8XL_J2) Applied Applied (standard)
2.5.2.3 Setting the Joint #3 Work Envelope
Remove the mechanical stop installed as standard and install the variable mechanical stop (J3). (Joint #3 standard work
envelope -61 to +202°)
Hexagon socket head cap bolt: M6 × 15 × 2 bolts
Strength: Compliant with ISO 898-1 property class: 10.9 or 12.9
Tightening torque: 13.0 ± 0.6 N·m (133 ± 6 kgf·cm)
f g
Angle (°) -51, +192 -61, +202
Pulse
C8-C901*** (C8L) -1856859, +6990528 -2220949, +7354618
C8-C1401*** (C8XL) -3342336, +12582912 -3997696, +13238272
Variable Mechanical Stop (J3) Applied Applied (standard)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
66
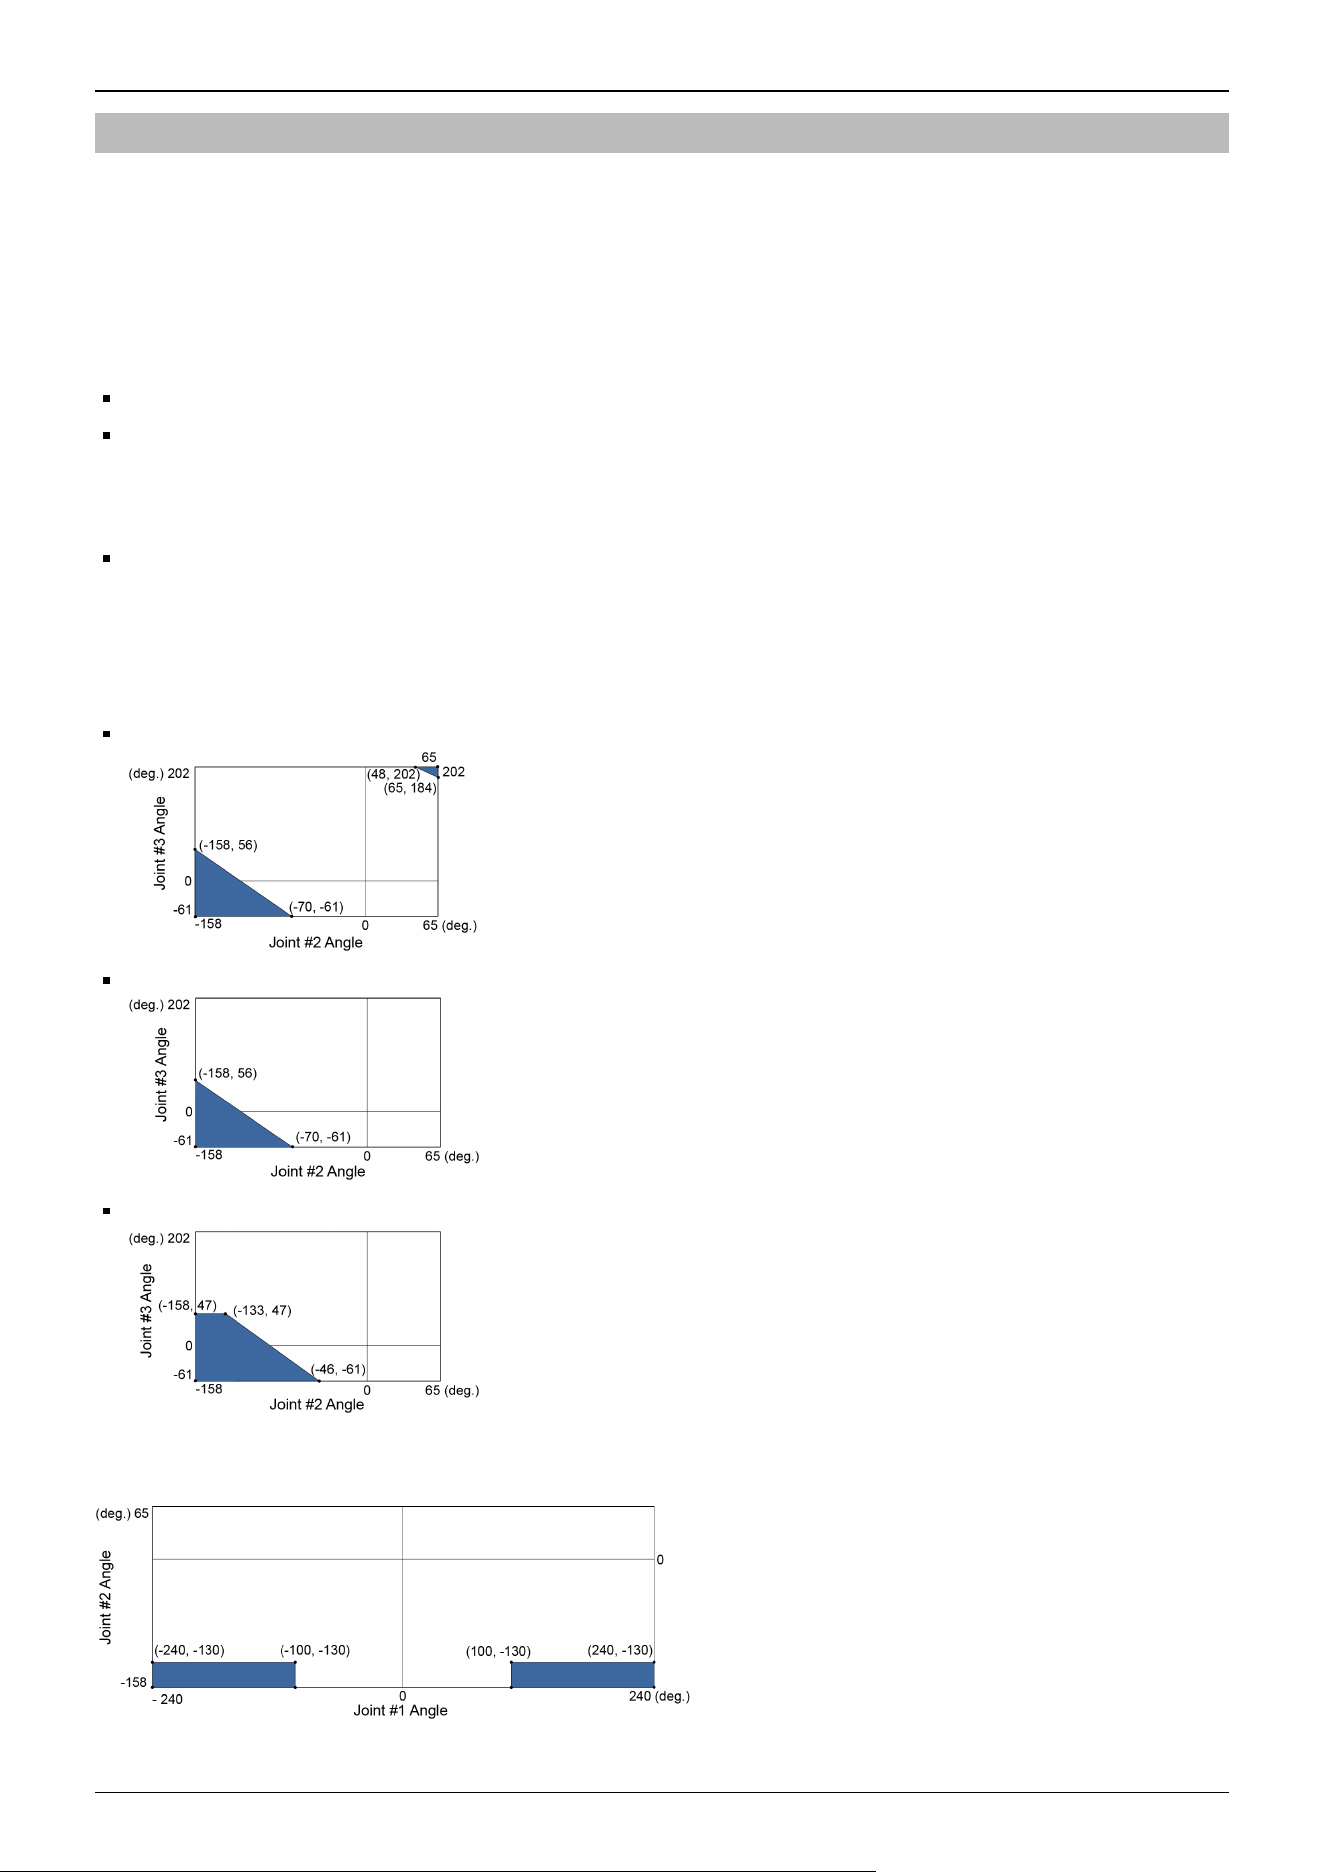
2.5.3 Restriction of Manipulator Operation by Joint Angle Combination
To prevent the arms of the Manipulator from interfering each other, the Manipulator operation is restricted in the specified
motion range according to the angle combination of the Joint #1, #2, and #3.
The Manipulator operation is restricted and the Manipulator stops when the joint angles are within the colored areas in the
following figure.
The restriction to Manipulator operation is enabled:
During CP motion command execution
When you attempt to execute the motion command for moving the Manipulator to a target point (or pose) in the specified
motion range.
The restriction to the Manipulator operation is disabled:
The Arms of the Manipulator momentarily go through the specified motion range during the PTP motion command
execution even though the joint angles of the Arms are in the colored areas of the figures above.
C8-C901*** (C8L)
Combination of Joint #2 and #3
-50 deg. <= J1 <= 50 deg.
-115 deg. <= J1 < -50 deg. or 50 deg. < J1 <= 115 deg.
-240 deg. <= J1 < -115 deg. or 115 deg. < J1 <= 240 deg.
Combination of Joint #1 and #2
-240 deg. <= J1 <= -110 deg. or 110 deg. <= J1 <= 240 deg.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
67
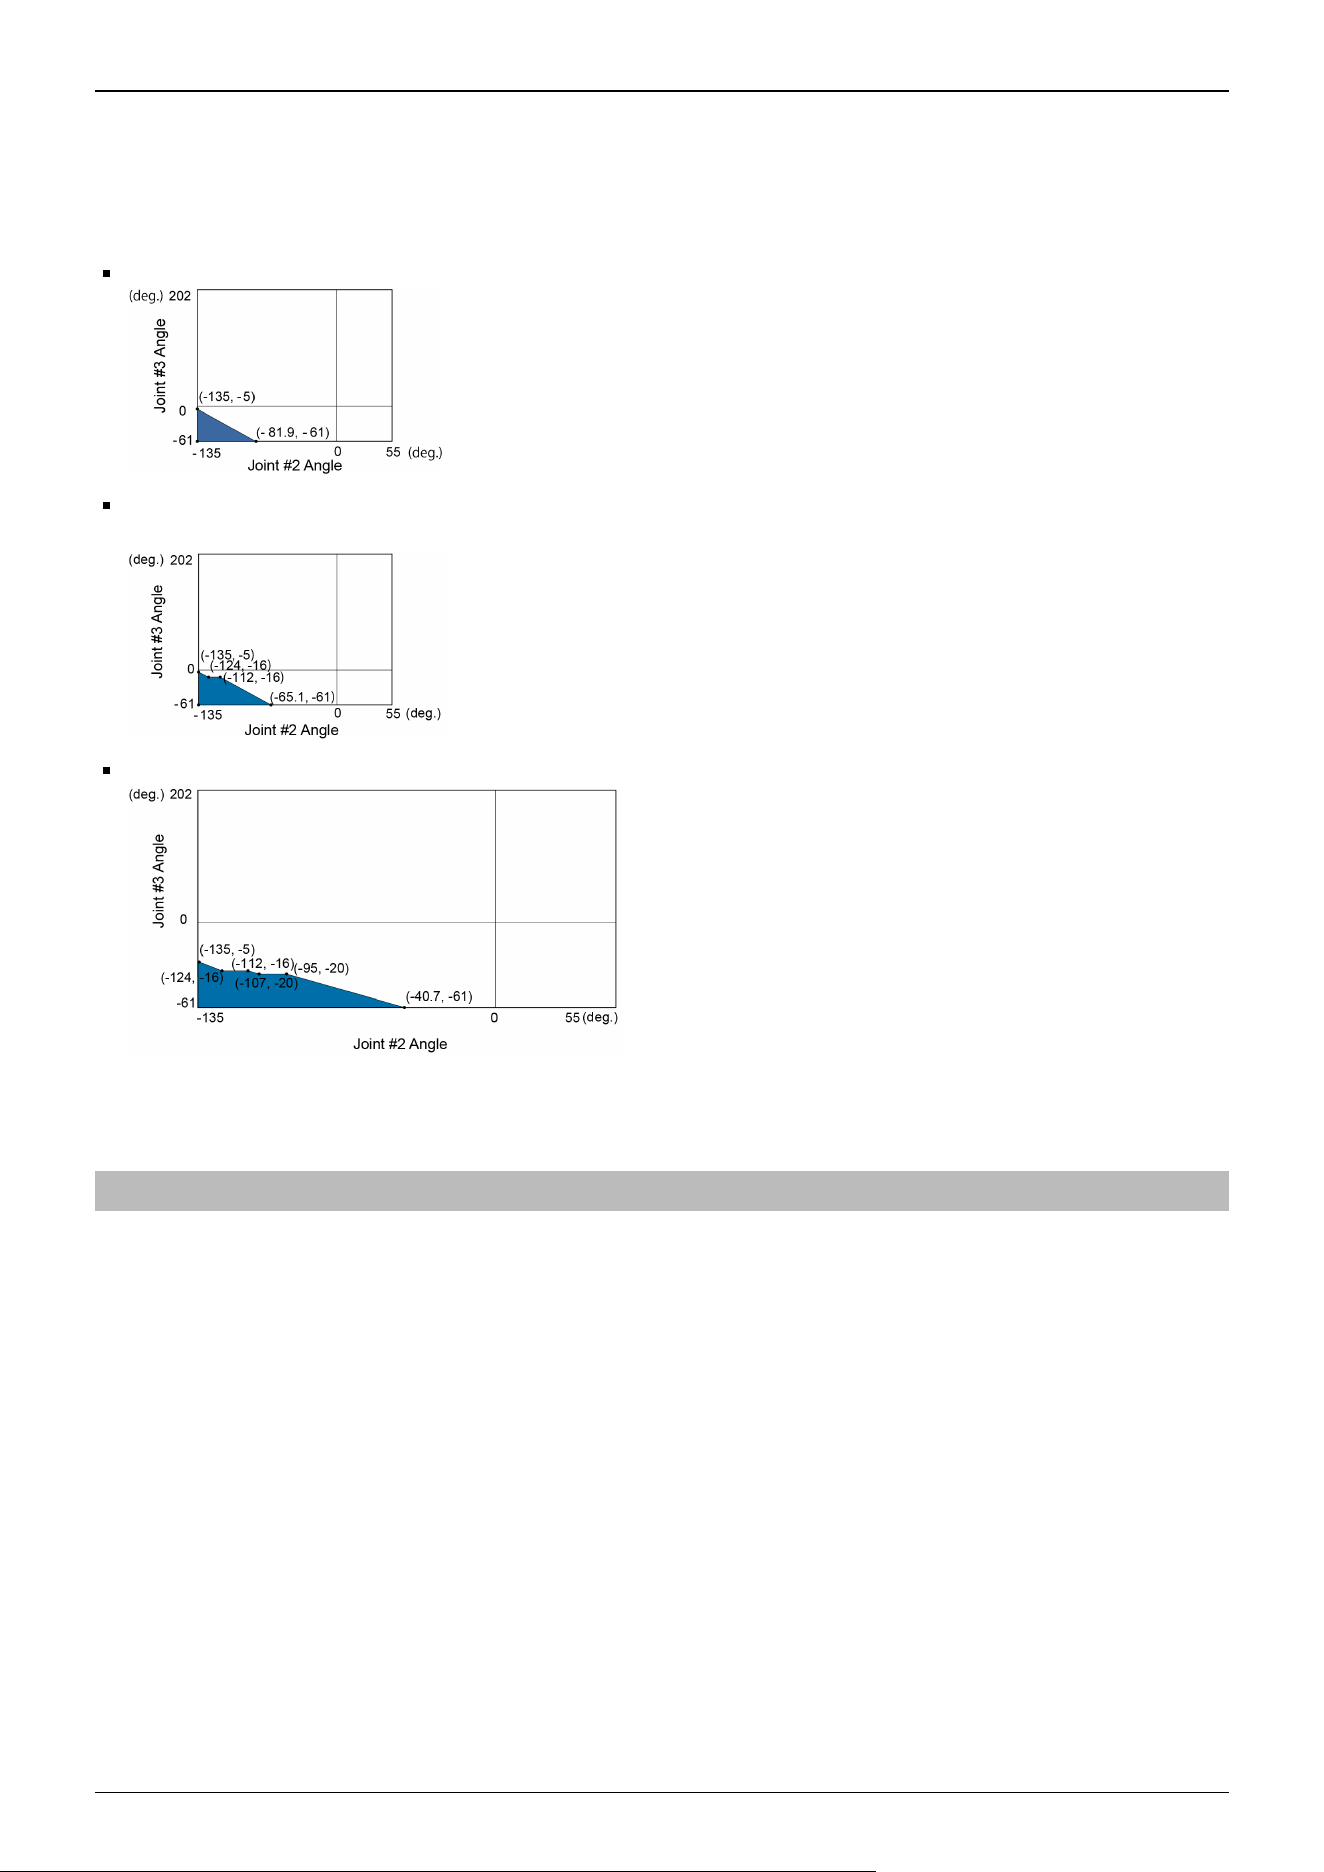
(deg.=°)
C8-C1401*** (C8XL)
Combination of Joint #2 and #3
-110 deg. <= J1 <= 110 deg.
-140 deg. < J1 < -110 deg. or 110 deg. < J1 < 140 deg.
-240 deg. < J1 < -220 deg. or 220 deg. < J1 < 240 deg.
-220 deg. <= J1 <= -140 deg. or 140 deg. < J1 < 220 deg.
(deg.=°)
2.5.4 Coordinate System
The origin point is where the Manipulator’s installation face intersects with the rotation axis of Joint #1.
For details on the coordinate system, refer to the Epson RC+ Users Guide manual.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
68
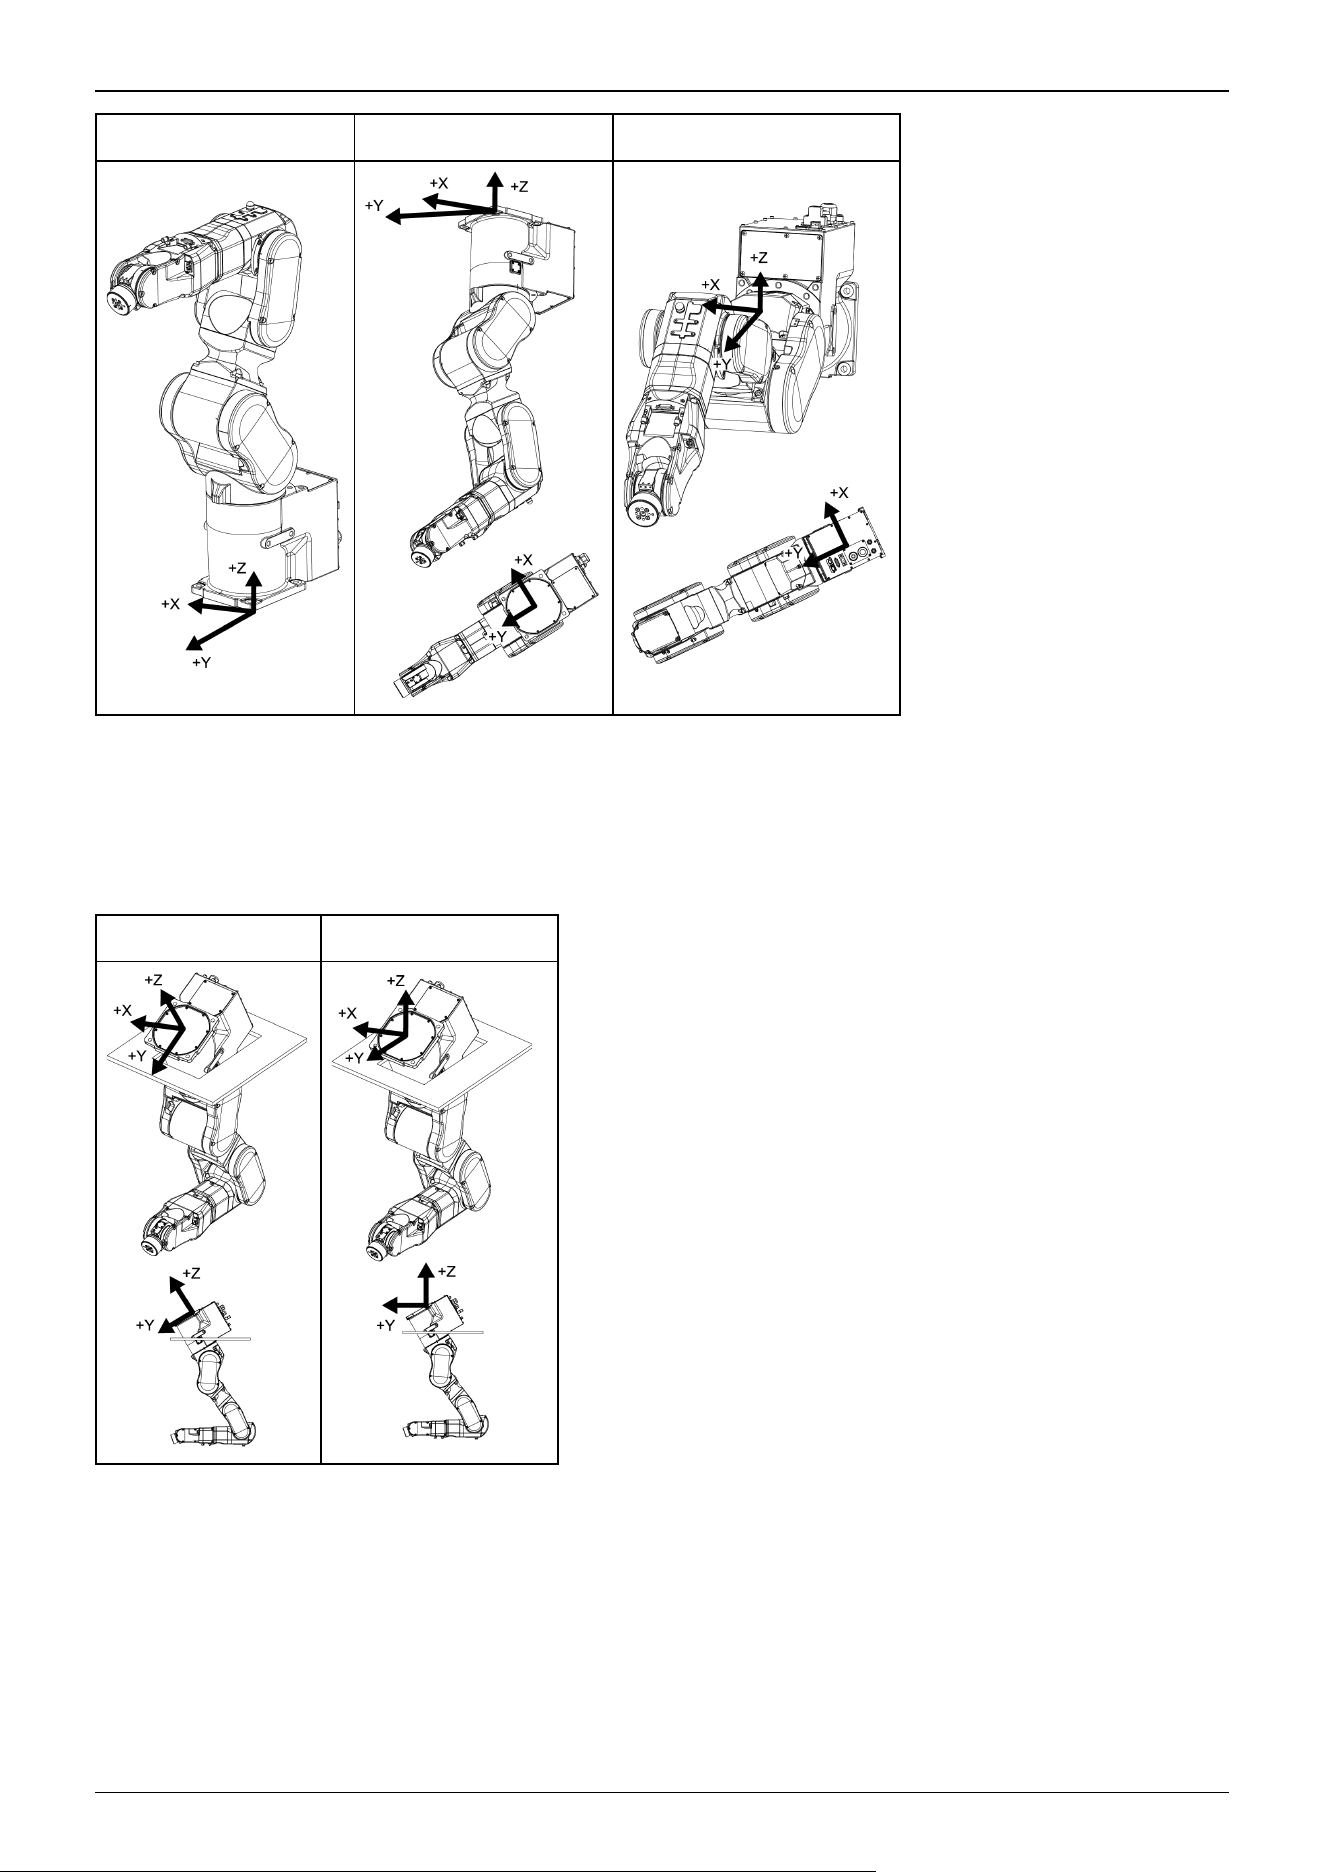
Table top mounting Ceiling mounting Wall mounting
BASE setting is suitable for install the robot obliquely.
BASE setting can change a specific coordinate system of the robot and match the World coordinate system of the Jog & Teach
and the coordinate system of the equipment.
For procedure of the BASE setting, refer to SPEL+ Language Reference: BASE Command.
With BASE setting Without BASE setting
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
69
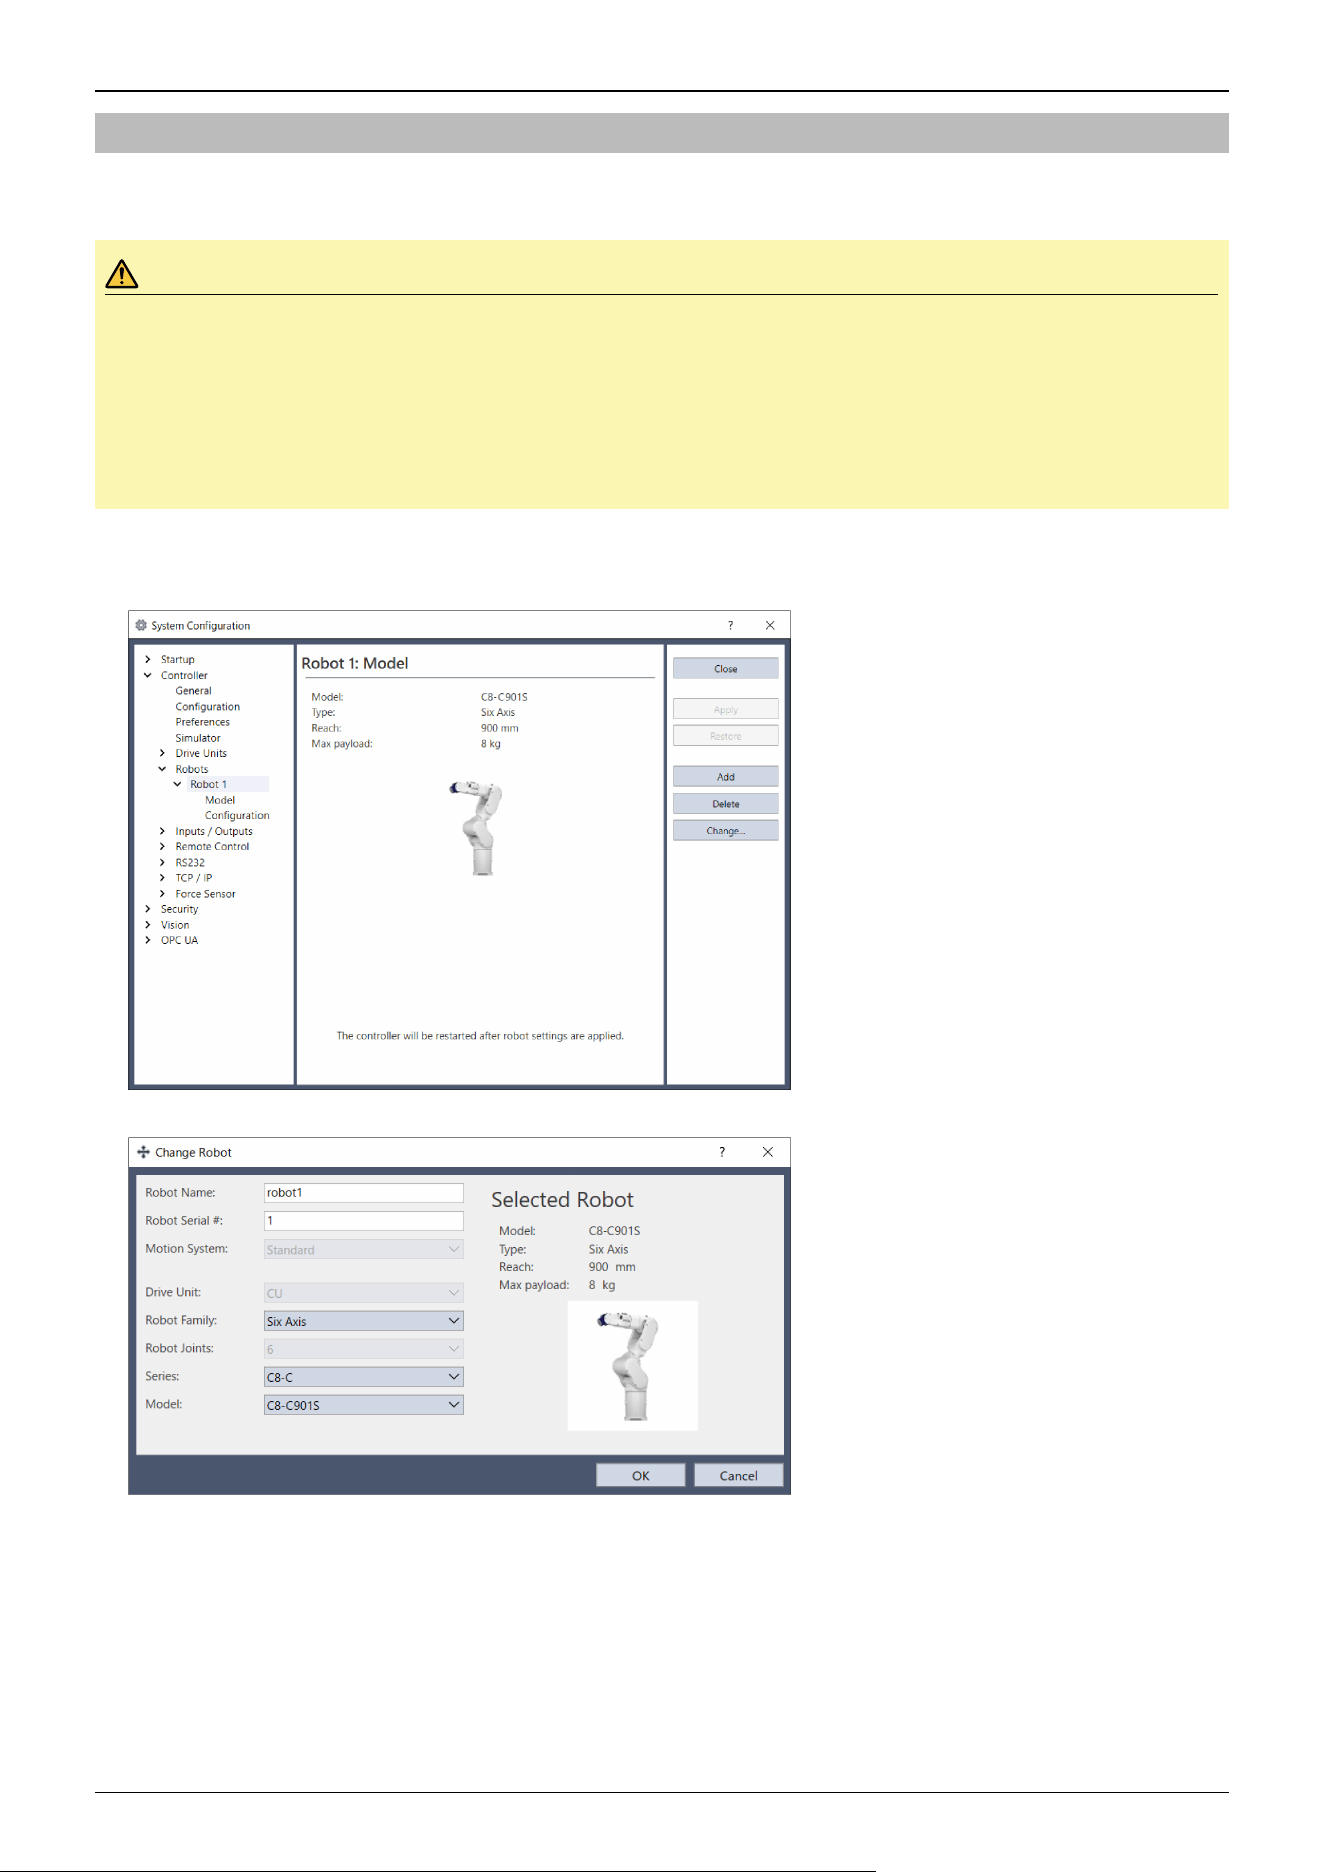
2.5.5 Changing the Robot
This section describes how to change the Manipulator model on Epson RC+.
CAUTION
Changing the Manipulator should be done with great caution. It initializes the robot calibration parameters (Hofs,
CalPls), additional axis information, and PG parameter data. Before changing the robot, make sure to save the
calibration data by following the procedure below.
1. Select the Epson RC+ menu-[Setup]-[System Configuration].
2. Select [Controller]-[Robots]-[Robot**]-[Calibration] from the tree list. Then, click [Save].
1. Select the Epson RC+ menu-[Setup]-[System Configuration].
2. Select [Controller]-[Robots]-[Robot**] from the tree list. (Dialog image: Epson RC+ 8.0)
3. Click the [Change] button. The following dialog box will be displayed.
4. Input the robot name and serial number printed on the name plate of the Manipulator. Any serial number can be entered.
However, enter the number printed on the Manipulator.
5. Select the robot type in the [Robot type] box.
6. Select the series name of the Manipulator in the [Series] box.
7. Select the robot model in the [Model] box.
Available robots will be displayed according to the format of the currently installed motor driver. When [Dry run] is used,
all the Manipulators of the series selected in Step 6 will be displayed.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
70
8. Click the [OK] button. The Controller is restarted.
2.5.6 Setting the Rectangular Range in the XY Coordinate System of the
Manipulator
The Cartesian (rectangular) range in the XY coordinate system of the Manipulator is specified by the limited Manipulator
operation area and the XYLIM setting. The limited Manipulator operation area is defined so that the hand does not interfere
with the rear side of the Manipulator. The XYLIM setting that you can determines the upper and lower limits of the X and Y
coordinates.
These settings are software-based limit, and so it does not change the maximum physical range. The maximum physical range
is based on the position of the mechanical stops.
These settings are disabled during a joint jogging operation. Therefore, be careful not to allow the hand to collide with the
Manipulator or peripheral equipment.
Go to [Tools] - [Robot Manager] - [XYZ Limits] panel, and make the setting. This can also be set using the XYLim statement
in [Command Window].
2.6 Options
C8 series Manipulator has the following options.
Brake Release Unit
Camera Plate Unit
Tool Adapter (ISO flange)
Variable Mechanical Stop
User Wires and Pneumatic Tubes
2.6.1 Brake Release Unit
While the electromagnetic brake is on (such as in emergency mode), you cannot move any arm by pushing manually. You can
move the Arms by hand using the brake release unit while the Controller power is off or right after unpacking.
KEY POINTS
Precautions regarding the brake release unit
Be sure to prepare at least one set of the brake release unit.
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
71
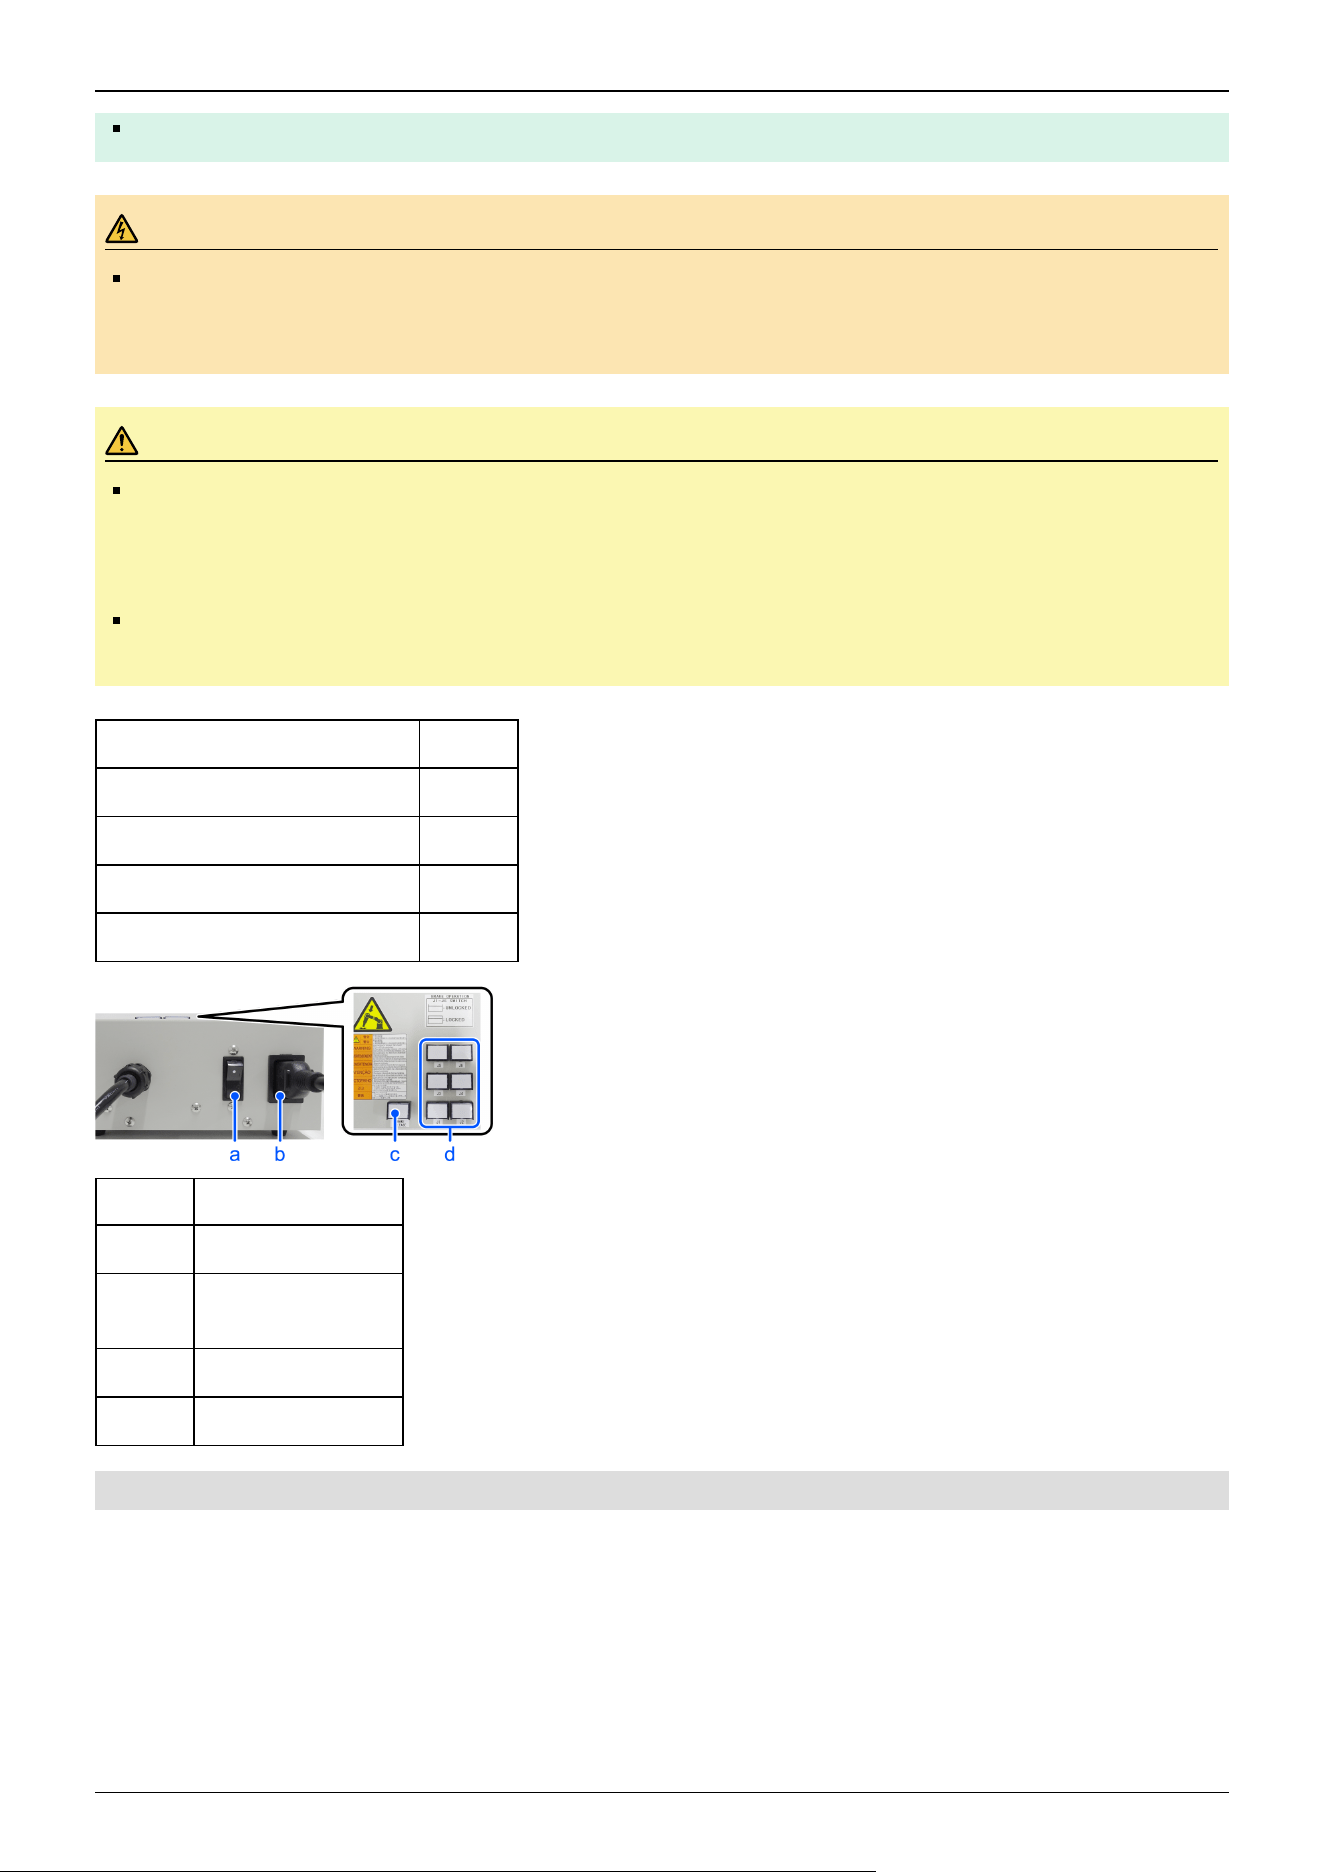
Place at easy-to-reach location so that you can use it immediately when in a emergency situation.
WARNING
Turn off the power to the Robot Controller and brake release unit when connecting or replacing the brake
release unit or external short connector. Inserting or removing connectors with the power on may result in
electric shock and/or malfunction of the robot system.
CAUTION
Normally, release the brakes of joints one at a time. If the brakes of two or more joints must be released
simultaneously due to unavoidable reasons, use extreme care. Releasing the brakes of multiple joints
simultaneously may cause the arm to fall in an unexpected direction, resulting in hands or fingers getting
caught or damage or failure of the Manipulator.
After releasing the brake, the arm may fall by its own weight or move to the unexpected direction. Make sure
to prepare a countermeasure to prevent the arm from falling and check the operation environment is safe.
Width 180 mm
Depth 150 mm
Height 87 mm
Weight (Cables are not included.) 1.7 kg
Cable to the Manipulator 2 m
Symbol Description
a Power switch
b
Power Cable
(You must provide.)
c Power lamp
d Brake release switch
2.6.1.1 Power Cable
You must provide a power cable. Be sure to use the specifications below.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
72
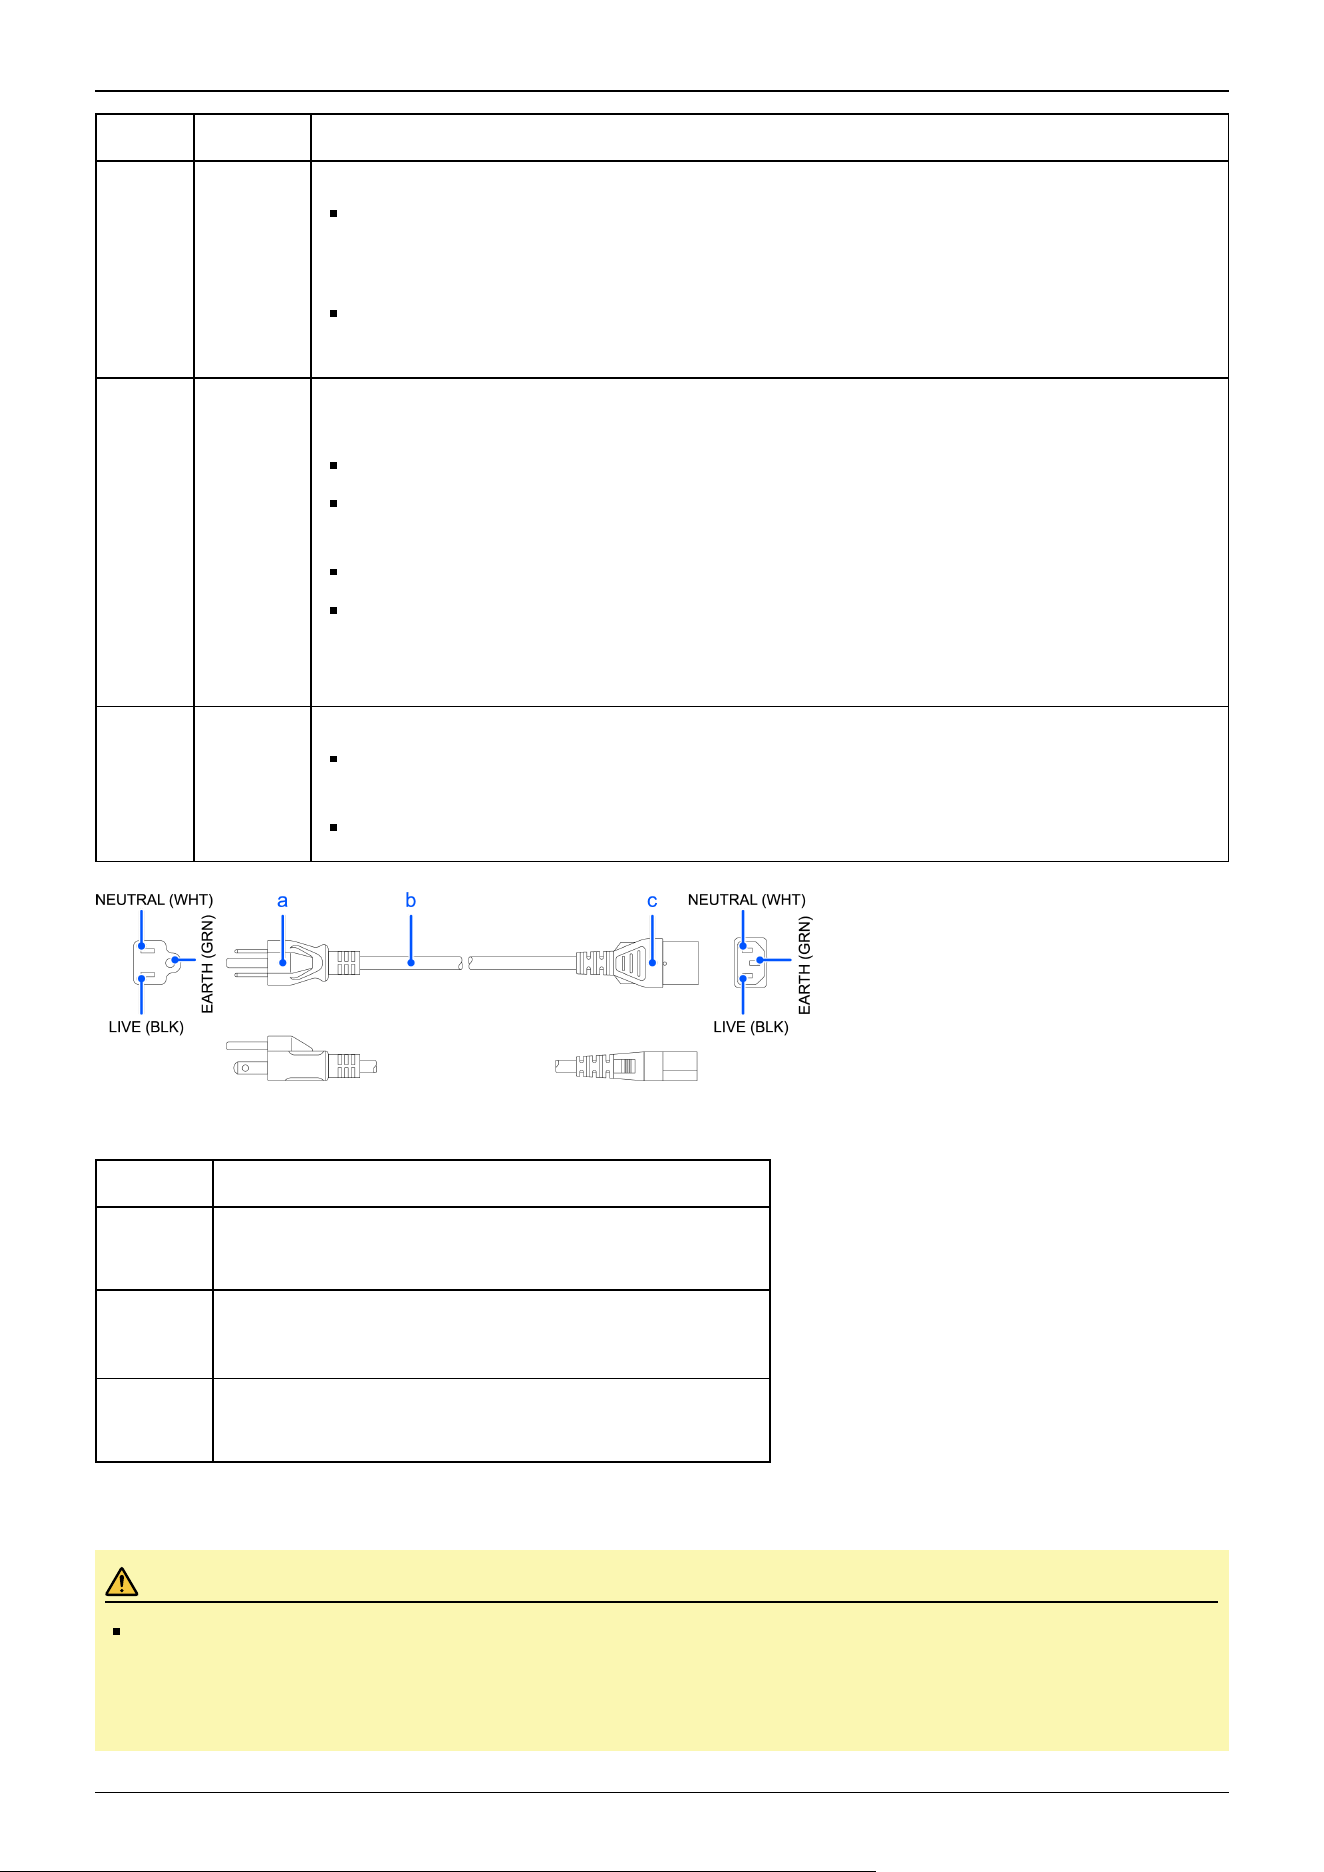
Symbol Item Specifications
a Plug
Comply with local safety regulation
Class I (2P + PE), AC250 V, 6 A or 10 A
Ex.: CEE Pub.7 Certified, CCC Certified, KC Certified, BS1363 Certified, PSB Certified, BIS
Certified, SABS Certified
Class I (2P + PE), AC125 V, 7 A, 12 A, or 15 A etc.
Ex.: UL Certified, PSE Certified, BSMI Certified
b
Flexible
cable
Comply with IEC/EN standards or local safety regulation
Example:
IEC 60227-1: General requirements
IEC 60227-5: Polyvinyl chloride insulated cables of rated voltages up to and including 450/750
V - Part 5: Flexible cables (cords)
EN 50525-1: General requirements
EN 50525-2-11: Electric cables - Low voltage energy cables of rated voltages up to and
including 450/750 V (Uo/U) - Part 2-11: Cables for general applications - Flexible cables with
thermoplastic PVC insulation
c
Appliance
coupler
Comply with IEC/EN standards or local safety regulation
IEC / EN 60320-1: Appliance couplers for household and similar general purposes - Part 1:
General requirements
Standard Sheet C13: AC250 V/10 A
For Japan
Item Specifications
Plug
PSE Certified
Class I (2P+PE), AC125 V, 7 A or higher
Code
PSE Certified
0.75 mm
2
or more
Connector
PSE Certified
IEC 60320-1 Standard Sheet C13: AC125 V/10 A or higher
Precautions for use
CAUTION
Operating the Manipulator without a brake release unit or external short connector connected may cause the
brake to fail to release, possibly damaging the brake.
After using the brake release unit, be sure to connect the external short circuit connector to the Manipulator or
make sure to leave the connector for the brake release unit connected.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
73
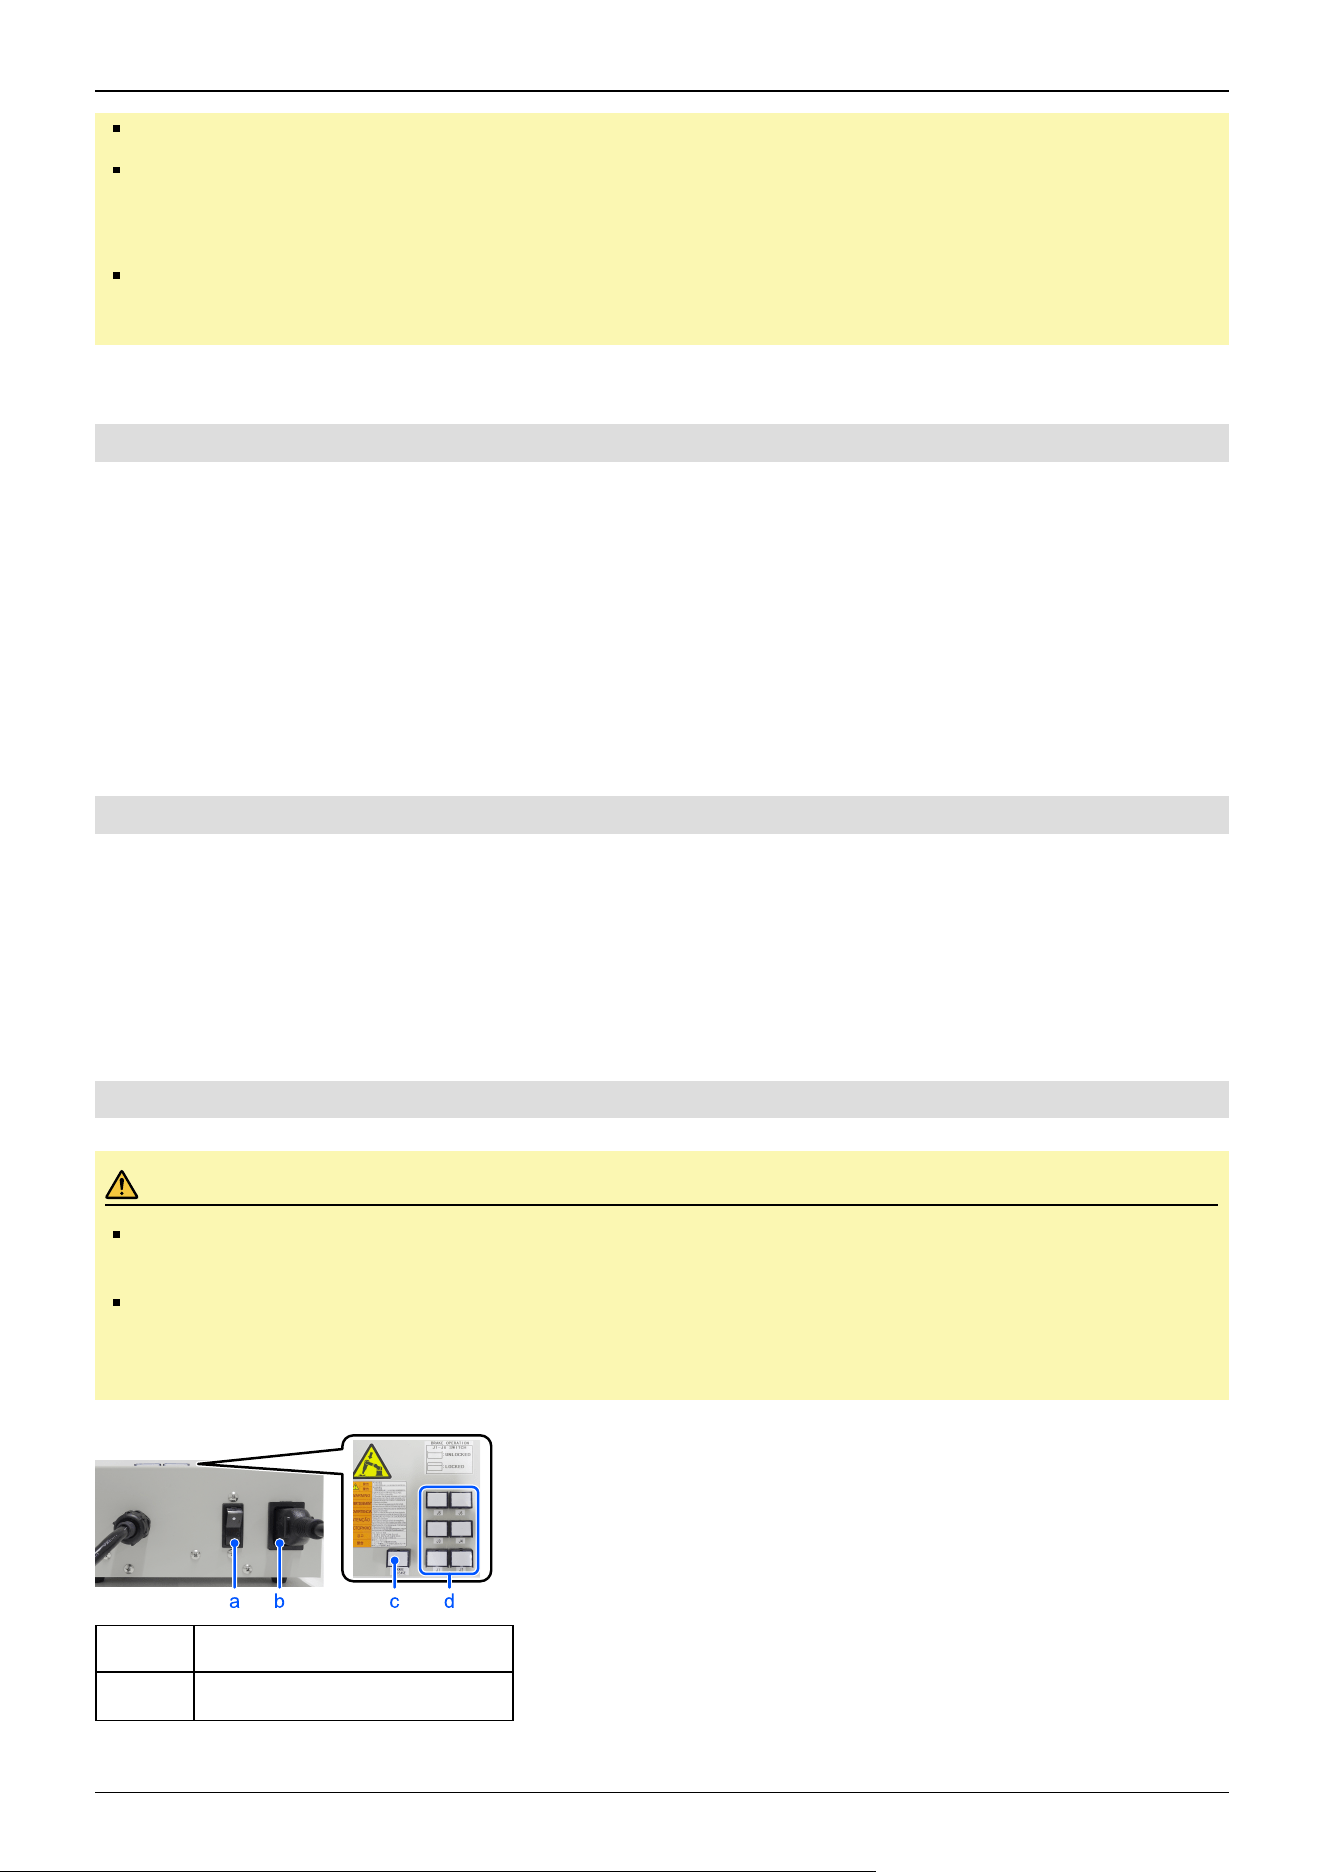
Keep the external short connector. Otherwise you cannot release the brakes.
If you turn on the brake release unit while the brake release switch is being pressed, an unintended arm may
move downward. Before turning on the brake release unit, make sure that the brake release switch is not
pressed.
If you turn on the brake release unit without the connector, it may lead to the short for the male pin used in the
connector. Before turning on the brake release unit, make sure that the connector is connected.
2.6.1.2 Installing the Brake Release Unit
1. Turn off the Controller.
2. If the M/C power cable is not connected to the Controller:
Connect the M/C short connector, or connect the Controller.
(Keep the Controller power off.)
If the M/C power cable is already connected to the Controller:
Go to the step (3).
3. Remove the external short connector.
4. Connect the brake release unit to the connector of the connection cable.
2.6.1.3 Removing the Brake Release Unit
1. Turn off the brake release unit.
2. Remove the power cable of the brake release unit.
3. Disconnect the brake release unit from the connector of the connection cable.
4. If the M/C short connector is connected to the M/C power cable, remove the short connector.
5. Connect the external short connector to the connector of the connection cable.
2.6.1.4 How to Use the Brake Release Unit
CAUTION
After releasing the brake, the arm may fall by its own weight or move to the unexpected direction. Make sure
to prepare a countermeasure to prevent the arm from falling and check the operation environment is safe.
If the arm you released its brake moves awkwardly or faster than usual, stop the operation promptly and
contact the supplier. The brake release unit may be broken. If you keep operating the Manipulator, it may lead
to the breakdown of the Manipulator or you may get your hand or fingers caught.
Symbol Description
a Power switch
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
74
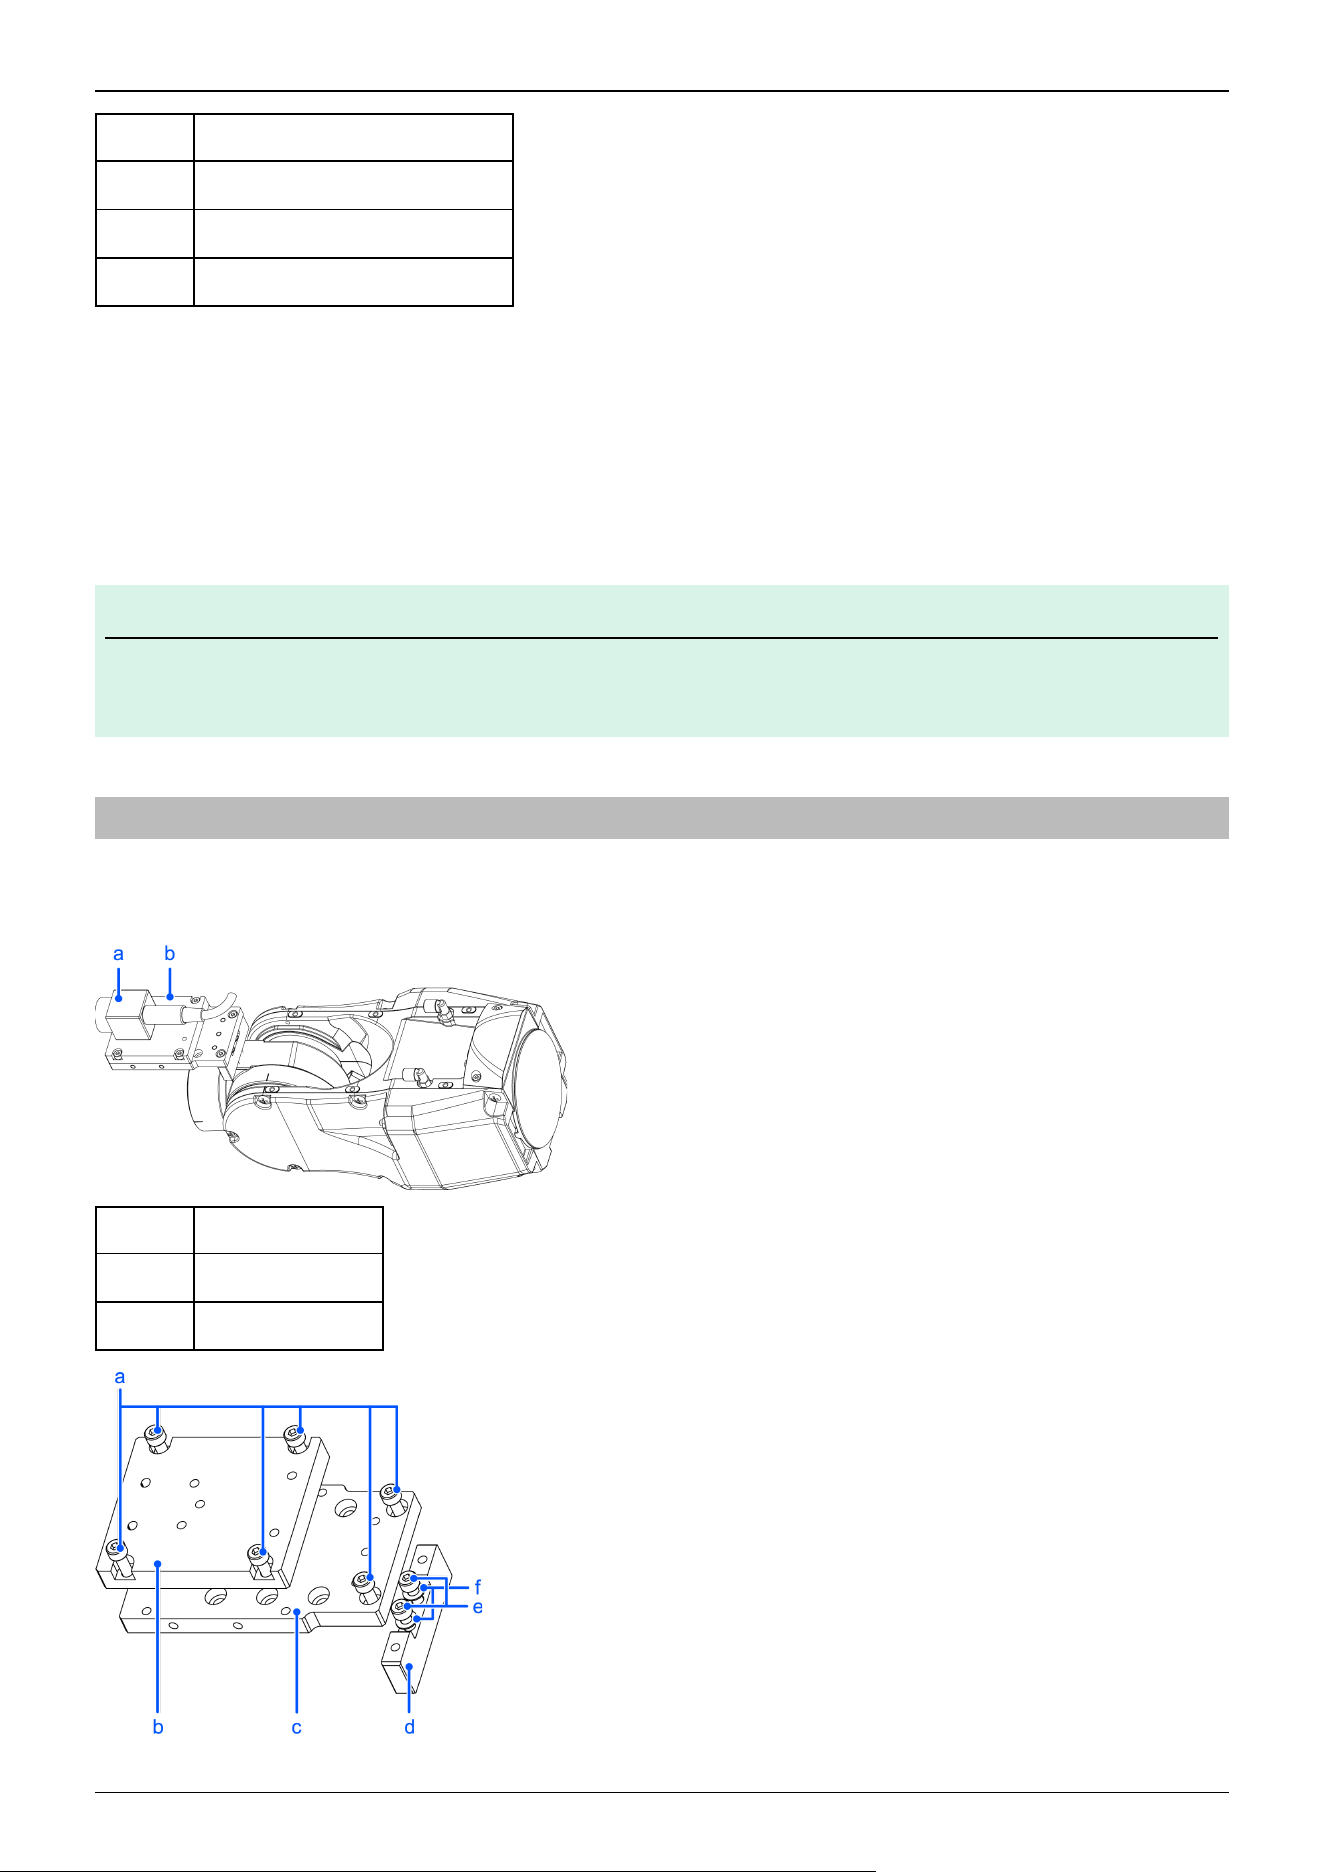
Symbol Description
b Power cable (You must provide.)
c Power lamp
d Brake release switch
1. Refer to “Installing the Brake Release Unit” above to connect the brake release unit to the connector of the connection
cable.
2. Plug the power cable into the brake release unit.
3. Plug the power cable into the power supply plug.
4. Turn on the brake release unit. When the brake release unit is enabled, the power lamp lights up.
5. Press the switch of the arm (J1 to J6) you want to move and then move the arm. Press the switch again. The brake will be
released. The brake will be enabled by pressing the switch once again.
KEY POINTS
Move the arm the brake is released by two persons or more (one presses the switch and one moves the arm).
The arm can be very heavy and needs the significant force to move.
2.6.2 Camera Plate Unit
To mount a camera to the C8 series Manipulator, you need to mount the camera plate unit first.
Appearance of arm end with camera
Symbol Description
a Camera
b Camera Plate Unit
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
75
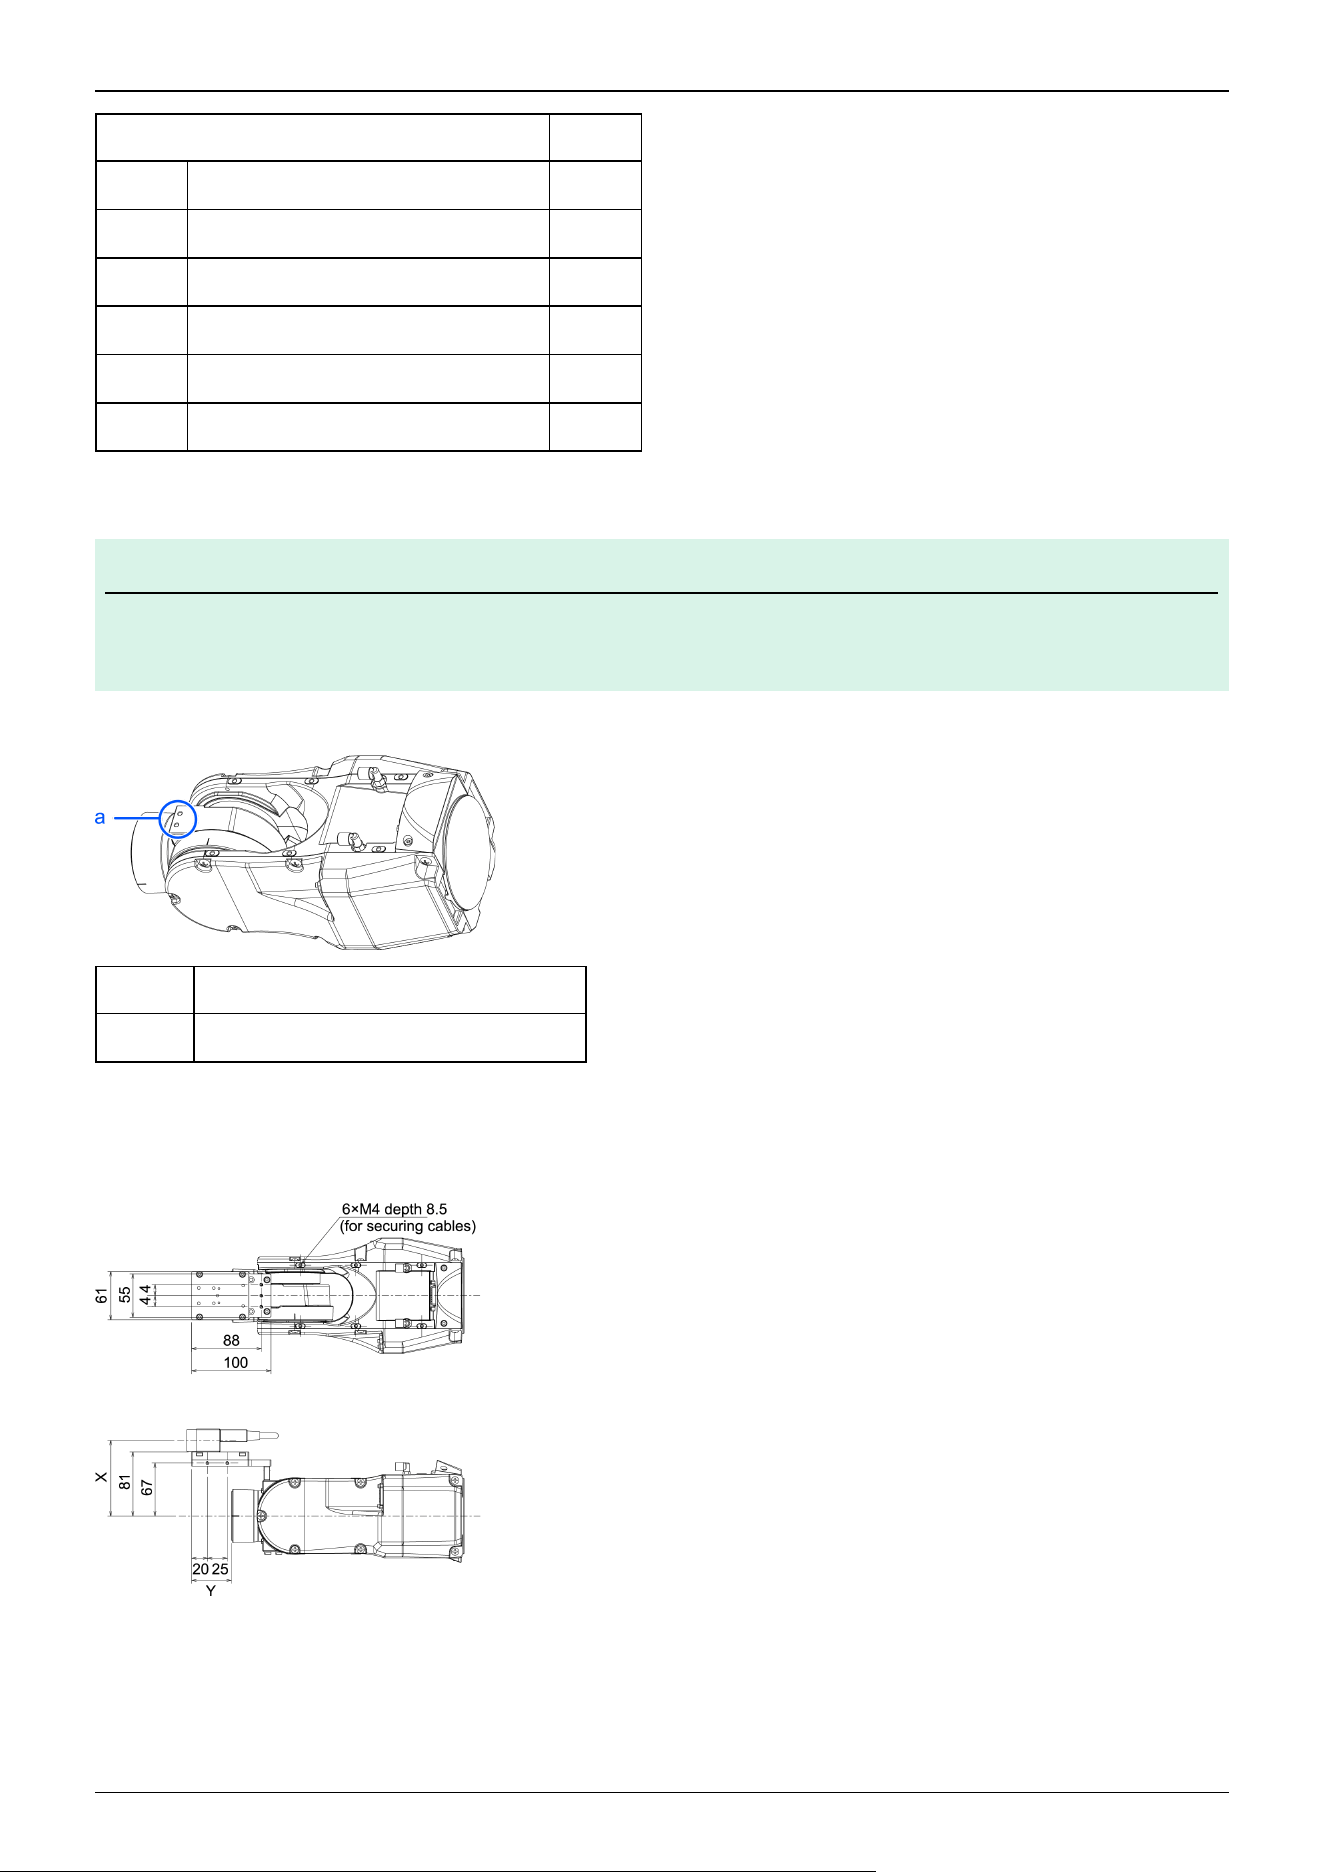
Parts Included Qty.
a Hexagon socket head cap bolt M4×12 6
b Camera adapter plate 1
c Camera mid plate 1
d Camera base plate 1
e Hexagon socket head cap bolt M4×20 2
f Plain washer for M4 (small washer) 2
Installation
KEY POINTS
For details of tightening the hexagon socket head cap bolt, refer to the following section.
Tightening the Hexagon Socket Head Cap Bolts
Mounting holes for the camera base plate on the C8 series Manipulator
Symbol Description
a Mounting holes for the camera base plate
For installation procedure, refer to the following manual.
"Epson RC+ Option Vision Guide Hardware & Setup"
Dimension of the camera plate unit
Dimensions X and Y will change depending on the position of camera mid plate and camera size. Refer to the table below for
the values.
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
76
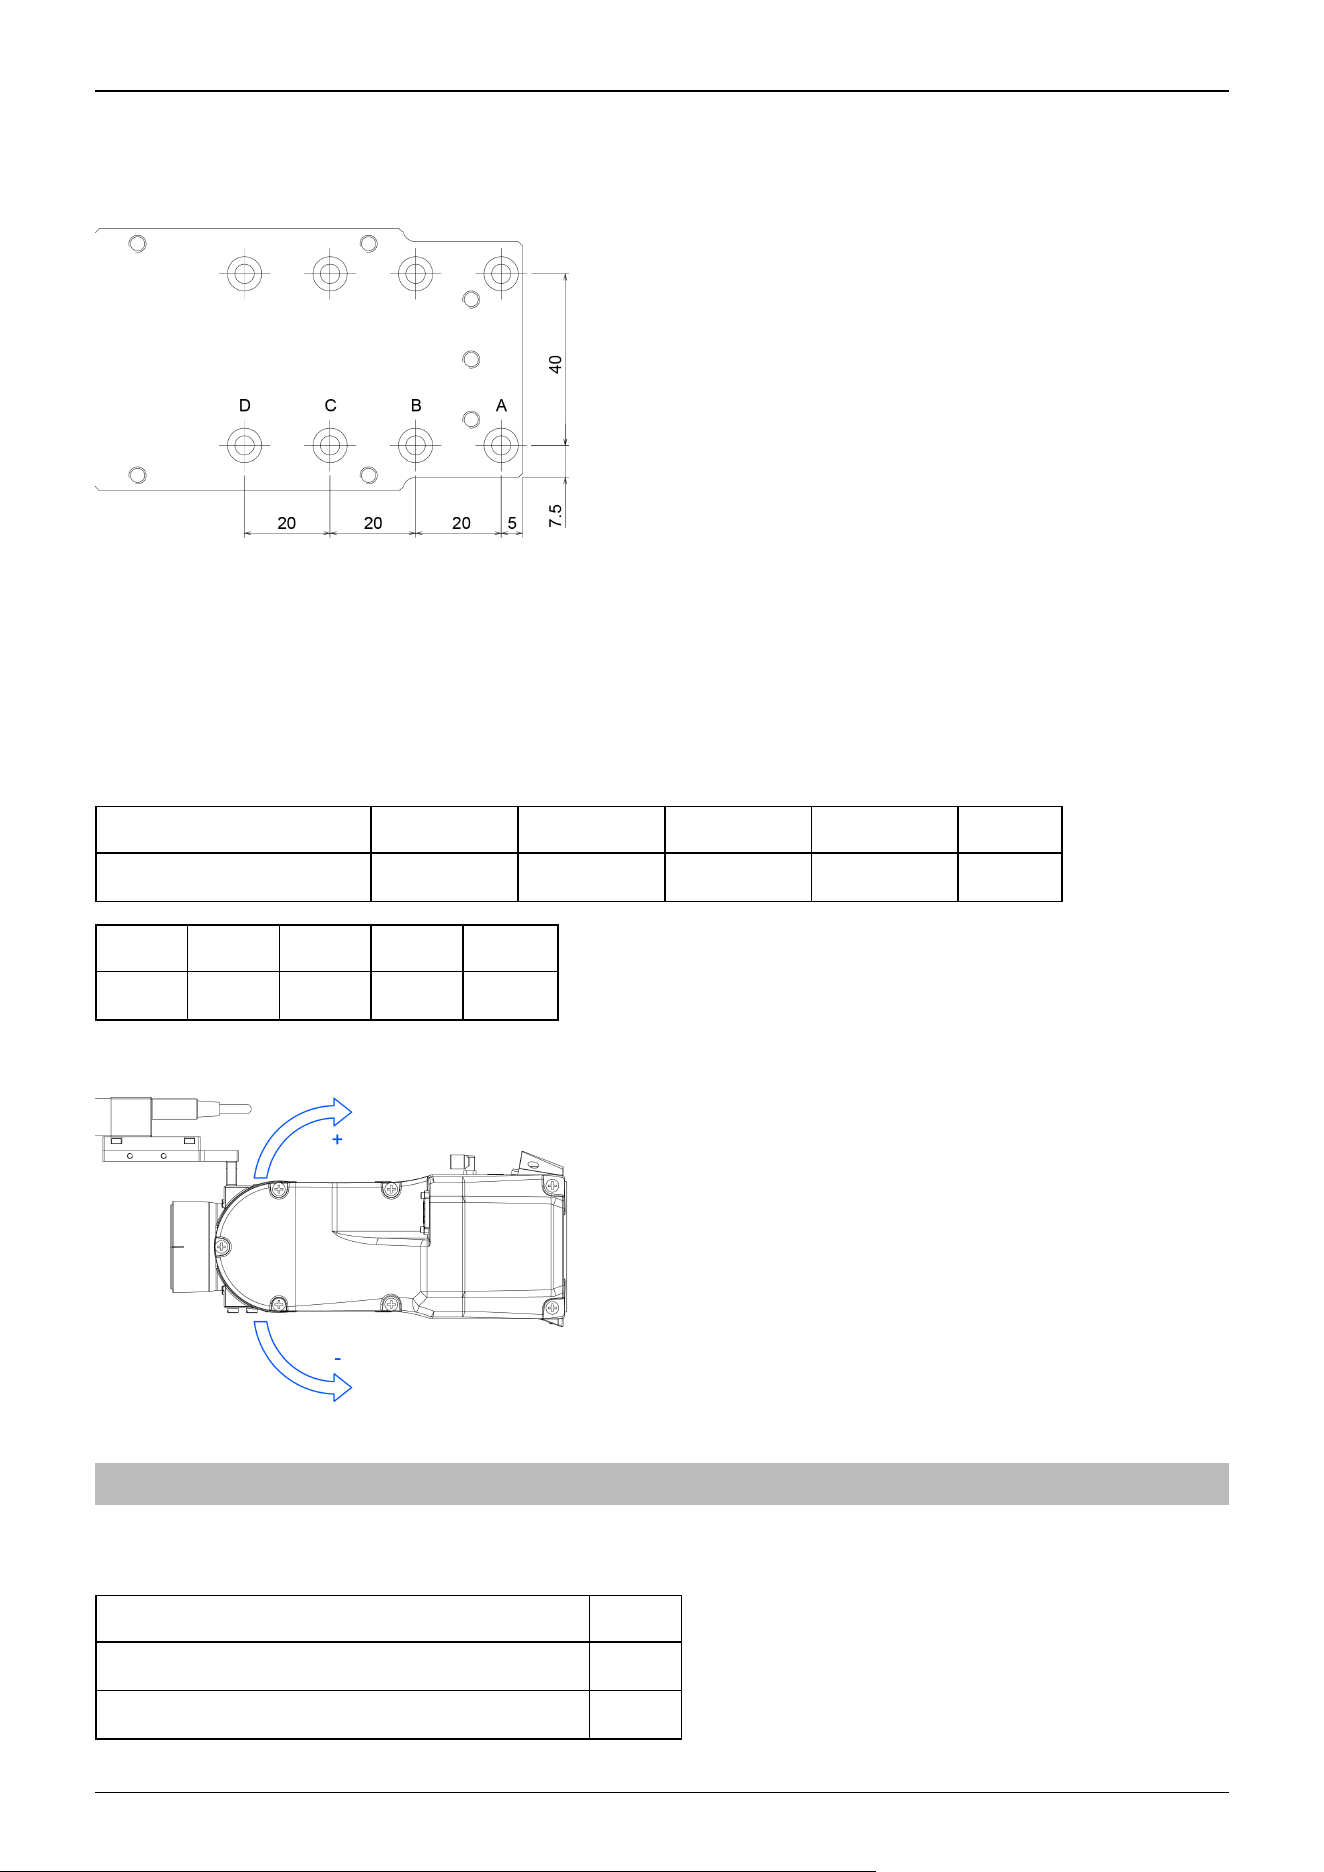
Camera mid plate
The camera mid plate uses the mounting holes A to D. By using the different mounting holes, it can be mounted to the camera
base plate in the different four positions.
Camera and C8 series Manipulator Joint #5 motion range (reference values)
The Joint #5 motion range varies depending on the mounting position of camera mid plate and the camera you are using.
The table below shows the motion range (reference values) based on the available cameras for this option and the mounting
positions of the camera mid plate. The values in the table may vary depending on how to secure the cables.
By changing the Y position, you can extend the distance from the hand mounting surface to the camera. Also, you can attach
the larger hand. However, be careful about the Joint #5 motion range that will be limited in this case.
A B C D X
USB Camera, GigE Camera -135° to +70° -135° to +60° -135° to +45° -135° to +35° 95.5 mm
A B C D
Y 50 mm 30 mm 10 mm -10 mm
Direction of the Joint #5 motion
2.6.3 Tool Adapter (ISO flange)
Using the tool adapter, you can mount the hand whose dimensions are designed for the ISO flange to the C8 series
Manipulators.
Parts Included Qty.
ISO flange 1
Flange 1
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
77
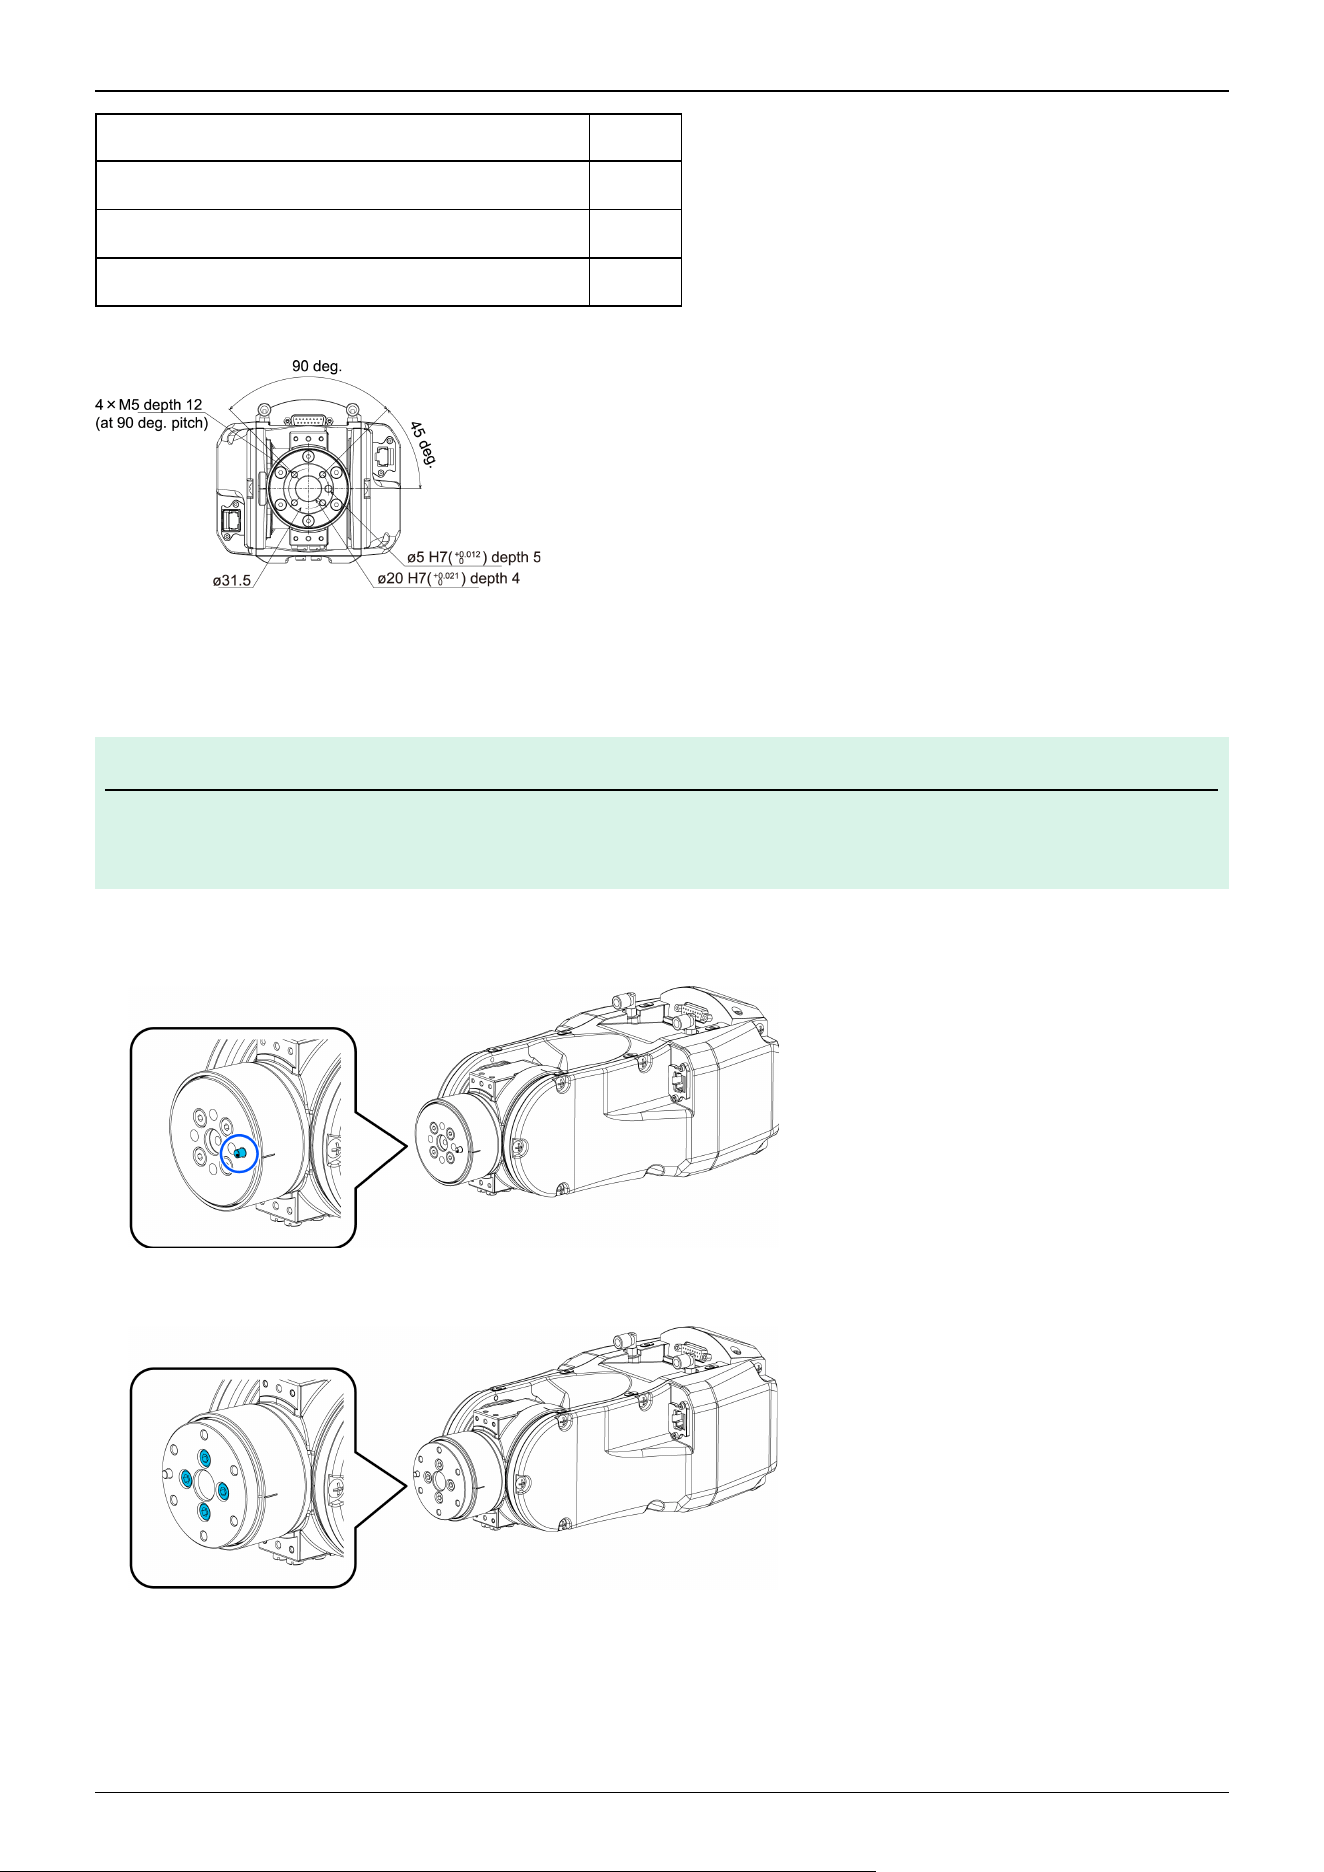
Parts Included Qty.
Pin 2
Hexagon socket head cap bolt with low head M5×10 6
Hexagon socket head cap bolt M5×15 4
Dimensions of ISO flange
* Each dimension and tolerance complies with ISO9409-1-31.5-4-M5.
ISO flange installation
KEY POINTS
For details of tightening the hexagon socket head cap bolt, refer to the following section.
Tightening the Hexagon Socket Head Cap Bolts
1. Press-fit the pin to the Arm #6 end flange.
Pin protrusion: 4 mm from the flange
2. Align the pin and the pin hole on the flange, and then mount the flange.
Hexagon socket head cap bolt: 4×M5×15
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
78
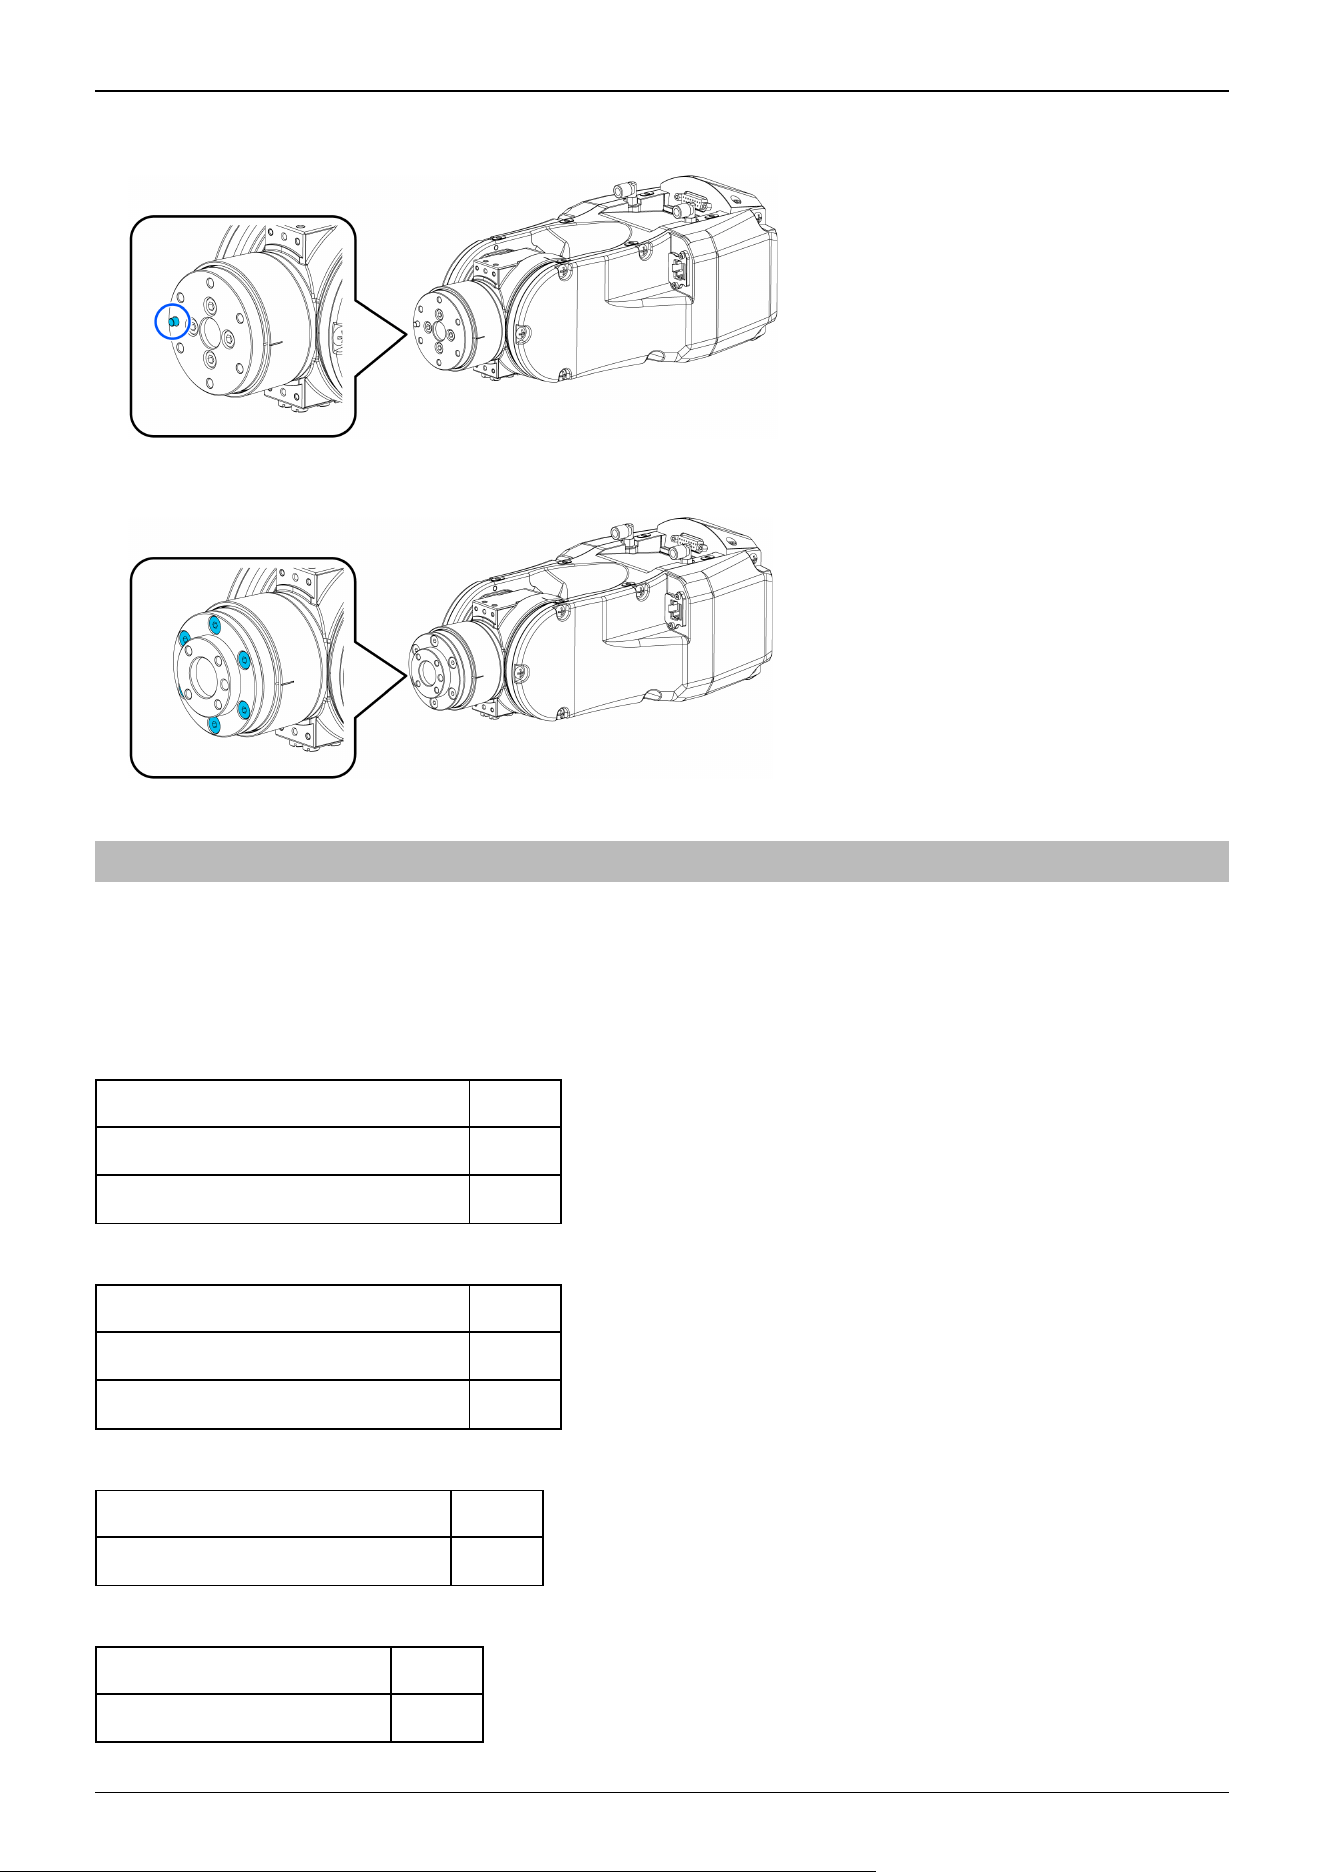
3. Press-fit the pin to the installed flange.
Pin protrusion: 4 mm from the flange
4. Align the pin and the pin hole on the ISO flange, and then mount the ISO flange.
Hexagon socket head cap bolt with low head: 6×M5×10
2.6.4 Variable Mechanical Stop
This option is used to mechanically limit the motion range of the Manipulator.
For installation and angle restriction measures, refer to the following section.
Setting the Work Envelope by Mechanical Stops
Variable Mechanical Stop (J1)
Parts Included Qty.
Variable Mechanical Stop (J1) 1
Hexagon socket head cap bolt M12×30 2
Variable mechanical stop (C8L_J2)
Parts Included Qty.
Variable mechanical stop (C8L_J2) 1
Hexagon socket head cap bolt M10×35 1
Variable mechanical stop (C8XL_J2)
Parts Included Qty.
Variable mechanical stop (C8XL_J2) 1
Variable Mechanical Stop (J3)
Parts Included Qty.
Variable Mechanical Stop (J3) 1
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
79
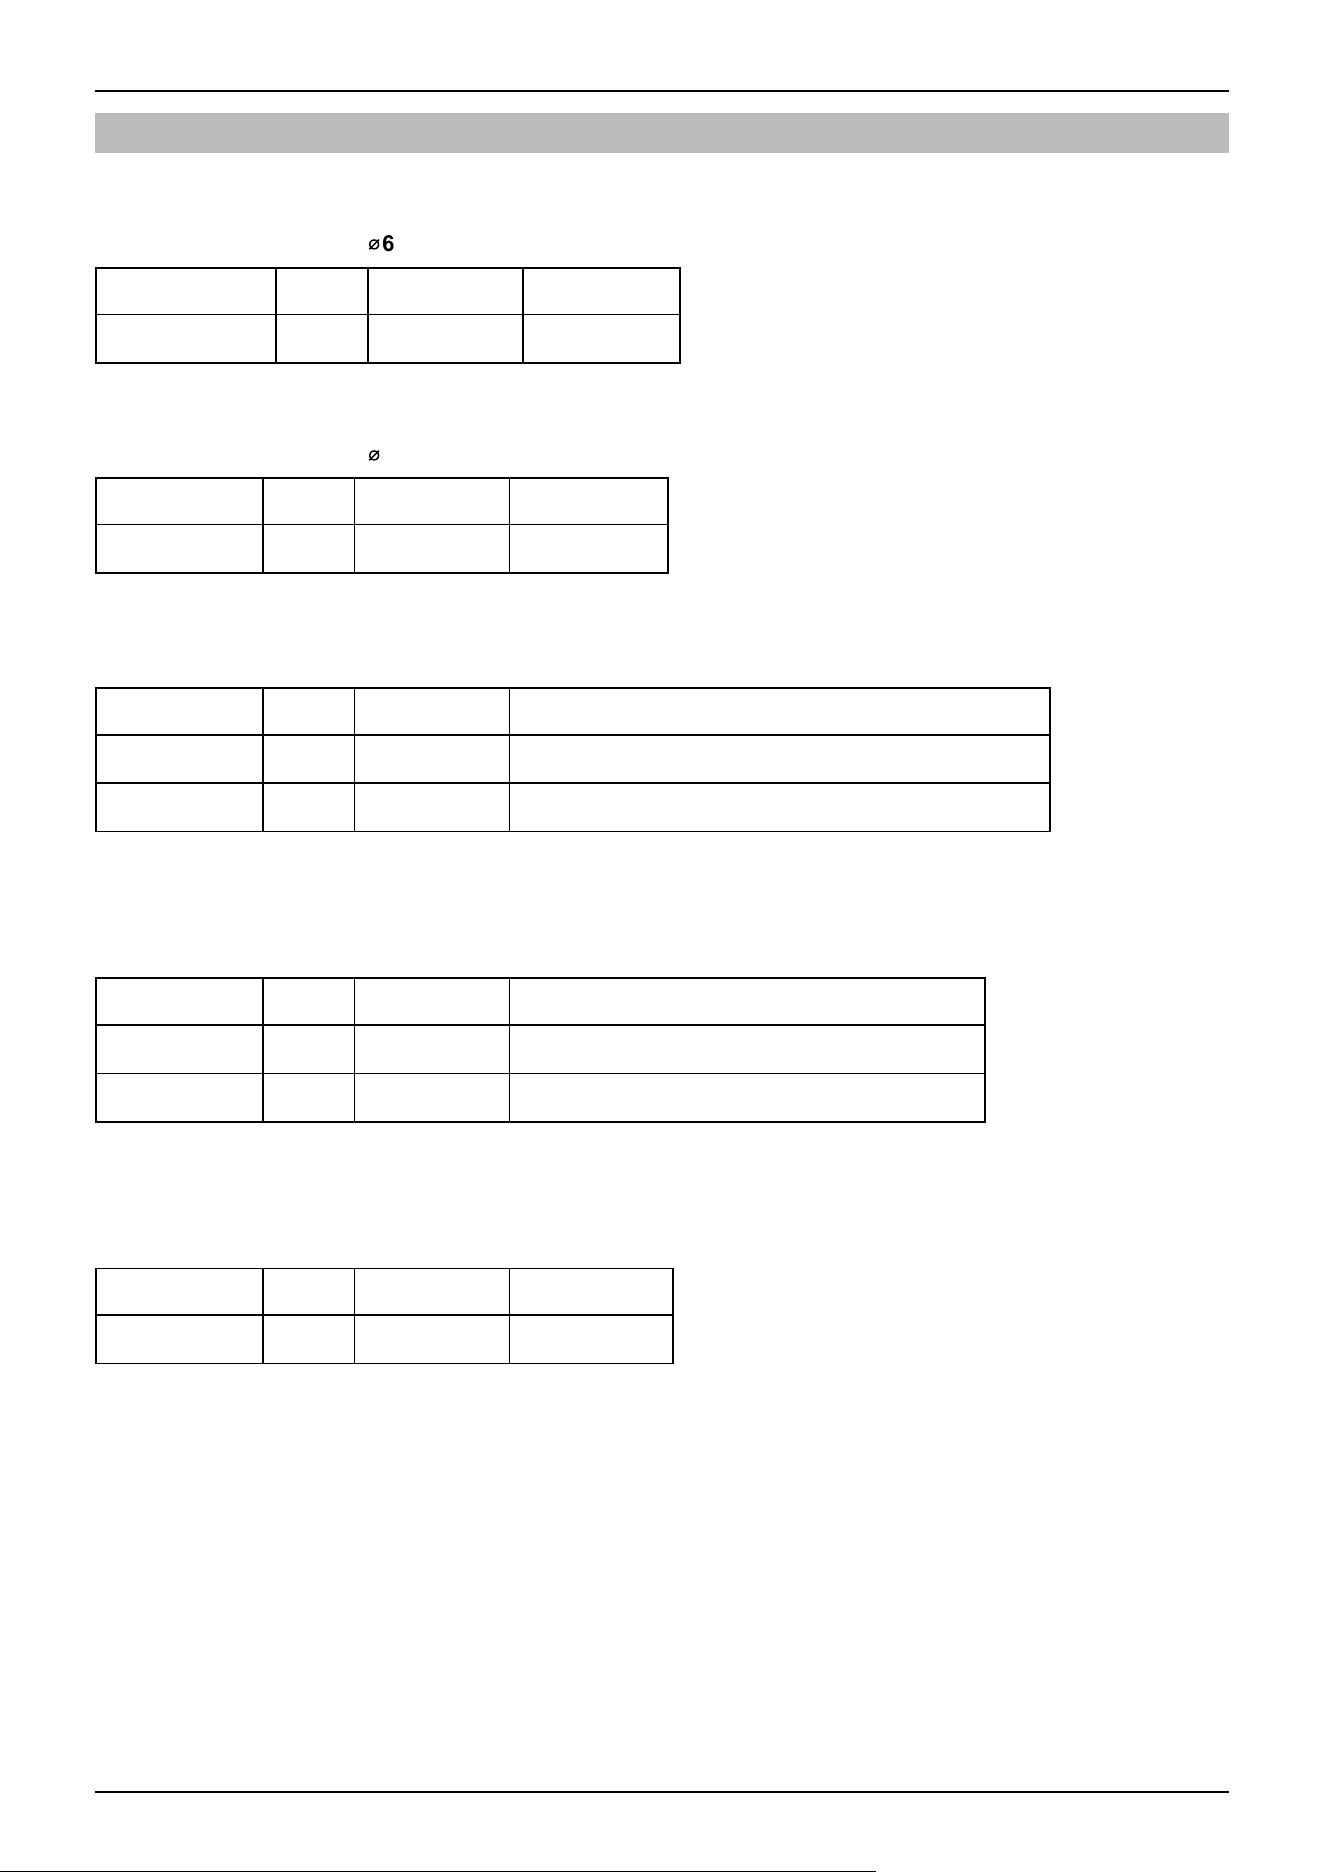
2.6.5 User Wires and Pneumatic Tubes
Use the following options when using the internal wiring and tubing for the hand drive.
Fitting for Customer Use (
⌀
6 Straight)
Parts Included Qty. Manufacturer Type
⌀6 straight fitting 2 SMC KQ2S06-M6N
* Attached as standard. The parts can be purchased additionally in case of lost or shortage.
Fitting for Customer Use (
⌀
6 Elbow)
Parts Included Qty. Manufacturer Type
⌀6 elbow fitting 2 SMC KQ2L06-M6N
* Attached as standard. The parts can be purchased additionally in case of lost or shortage.
Standard User Connector Kit (D-sub)
Parts Included Qty. Manufacturer Type
Connector 2 JAE DA-15PF-N (Solder type)
Clamp hood 2 HRS HDA-CTH (4-40) (10) (Connector setscrew: #4-40 UNC)
* Attached to standard and cleanroom-model Manipulators as standard. The parts can be purchased additionally in case of lost
or shortage.
Waterproof User Connector Kit (D-sub)
Parts Included Qty. Manufacturer Type
Connector 2 HARTING 09 67 015 5615 (Solder type)
Clamp hood 2 HARTING 09 67 015 0538 (Connector setscrew: #4-40 UNC)
* Attached to the protected-model Manipulators as standard. The parts can be purchased additionally in case of lost or
shortage.
Waterproof User Connector Kit (Ethernet)
Parts Included Qty. Manufacturer Type
Connector 2 HARTING 09 45 145 1560
* Not attached as standard. Please purchase the item if needed. Please note that the protection rating IP67 cannot be satisfied if
other connectors are used.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
80
3. C12 Manipulator
This chapter contains information for setup and operation of the Manipulators.
Please read this chapter thoroughly before setting up and operating the Manipulators.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
81
3.1 Safety
The Manipulator and its related equipment should be unpacked and transported by people who have received installation
training provided by Epson and the suppliers. Also, the laws and regulations of the installation country must be followed.
Before use, please read this manual and other related manuals to ensure correct use. After reading this manual, store it in an
easily accessible location for future reference.
This product is intended for transporting and assembling parts in a safely isolated area.
3.1.1 Conventions Used in This Manual
The following symbols are used in this manual to indicate important safety information. Be sure to read the descriptions shown
with each symbol.
WARNING
This symbol indicates an imminently hazardous situation which, if operation is not performed properly, will result
in death or serious injury.
WARNING
This symbol indicates a potentially hazardous situation which, if operation is not performed properly, could result
in an injury due to electric shock.
CAUTION
This symbol indicates a potentially hazardous situation which, if operation is not performed properly, may result in
a minor or moderate injury or in property damage only.
3.1.2 Design and Installation Safety
The robot system should be designed and installed by people who have received installation training provided by Epson and
the suppliers.
Design personnel should refer to the following manuals:
"Safety Manual"
"Controller Manual"
"Manipulator Manual"
Refer to the following section for the installation safety information.
Environment and Installation
Be sure to read this section and follow the safety information before installation to ensure that the installation work is
performed safely.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
82
3.1.3 Operation Safety
The following items are safety precautions for operating personnel:
WARNING
Be sure to read the Safety Manual before use. Operating the robot system without understanding the safety
information can be extremely dangerous and may result in serious injury or severe equipment damage.
Before operating the robot system, make sure that no one is inside the safety barriers. The robot system can
be operated in the teaching operation mode even when someone is inside the safety barriers. Even though
the motion of the Manipulator is always restricted (low speed and low power) to ensure operator safety, an
unexpected movement by the Manipulator can be extremely dangerous and may cause serious safety
problems.
If the Manipulator moves abnormally during operation of the robot system, immediately press the emergency
stop switch.
WARNING
To perform the power supply lockout, remove the power plug. Be sure to connect the AC power cable to a
power outlet. Do not connect it directly to a factory power source.
Before performing any replacement work, inform others in the area that you are working, and then turn off the
Controller and related equipment, and unplug the power cable from the power source. Performing any work
procedure with the power turned on is extremely dangerous and may result in electric shock and/or
malfunction of the robot system.
Do not connect or disconnect the connector of the M/C cable while the Controller is turned on. There is a risk
the Manipulator may malfunction, which is extremely hazardous. Also, performing any work procedure with
the power turned on may result in electric shock and/or malfunction of the robot system.
CAUTION
Whenever possible, only one person should operate the robot system. If it is necessary to operate with more
than one person, ensure that all personnel communicate with each other and take all necessary safety
precautions.
If the Manipulator is operated repeatedly with each joint having an operating angle of 5° or less, the bearings
used in the joints are likely to cause oil film shortage. Repeated operation may cause premature damage. To
prevent premature damage, operate the Manipulator to move each joint to an angle of 30° or more about
once per hour.
When the robot is operating at low speed (Speed: 5 to 20%), vibration (resonance) may occur continuously
during operation depending on the combination of the arm orientation and hand load. Vibration occurs due to
the natural vibration frequency of the arm and can be reduced by taking the following measures:
Changing the robot speed
Changing the teach points
Changing the hand load
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
83
3.1.4 Emergency Stop
Each robot system needs equipment that will allow the operator to immediately stop the system's operation. Install an
emergency stop device by using emergency stop input from the Controller or other equipment.
Before using the emergency stop switch, be aware of the following points.
The emergency stop switch should be used to stop the Manipulator only in case of emergencies.
Besides pressing the emergency stop switch when an emergency occurs, to stop the Manipulator during program operation,
use the Pause or STOP (program stop) statements assigned to a standard I/O.
The Pause and STOP statements do not turn off motor energization, and so the brake is not locked.
To place the robot system in emergency stop mode in a non-emergency (normal) situation, press the emergency stop switch
while the Manipulator is not operating.
Do not press the emergency stop switch unnecessarily while the Manipulator is operating normally.
It could shorten the lifespan of the following components.
Brakes
The brakes will be locked, which will shorten the lifespan of the brakes due to worn brake friction plates.
Normal brake lifespan:
About 2 years (when the brakes are used 100 times/day)
or about 20,000 times
Reduction gears
An emergency stop applies an impact to the reduction gear, which can shorten its life.
If the Manipulator is stopped by turning off the Controller while it is operating, the following problems may occur.
Reduced life and damage to reduction gear
Position shift at the joints
If a power outage or other unavoidable Controller power-off occurs during Manipulator operation, check the following points
after power is restored.
Damage in reduction gear
Shifting of the joints from their proper positions
If there was any shifting, maintenance is required. For more information, please contact the supplier.
Stopping distance of emergency stop
The Manipulator during operation cannot stop immediately after the emergency stop switch is pressed. Also, the stopping time
and movement distance vary depending on the following factors.
Hand weight, WEIGHT setting, ACCEL setting, workpiece weight, SPEED setting, movement posture, etc.
For the stopping time and movement distance of the Manipulator, refer to the following section.
Appendix B: Stopping Time and Stopping Distance at Emergency Stop
3.1.5 Safeguard (SG)
To maintain a safe working zone, safety barriers must be set up around the Manipulator, and safeguards must be installed at the
entrance and exit of the safety barriers.
The term "safeguard" as used in this manual refers to a safety device with an interlock that allows entry into the safety barriers.
Specifically, this includes safety door switches, safety barriers, light curtains, safety gates, safety floor mats, and so on. The
safeguard is an input that informs the Robot Controller that an operator may be inside the safeguard area. You must assign at
least one Safeguard (SG) in Safety Function Manager.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
84
When the safeguard is opened, Protective Stop operates to change to the safeguard open state (display: SO).
Safeguard open
Operations are prohibited. Further robot operation is not possible until either the safeguard is closed, the latched state is
released, and a command is executed, or the TEACH or TEST operation mode is turned on and the enable circuit is
activated.
Safeguard closed
The robot can operate automatically in an unrestricted (high power) state.
WARNING
If a third party accidentally releases the safeguard while an operator is working inside the safety barriers, this
may result in a hazardous situation. To protect the operator working inside the safety barriers, implement
measures to lock out or tag out the latch release switch.
To protect operators working near the robot, be sure to connect a safeguard switch and make sure that it
works properly.
Installing safety barriers
When installing safety barriers within the maximum range of the Manipulator, combine safety functions such as SLP. Carefully
take into account the size of the hand and the workpieces to be held so that no interference occurs between the operating parts
and the safety barriers.
Installing safeguards
Design the safeguards so that they satisfy the following requirements:
When using a key switch type safety device, use a switch that forcibly opens the interlock contacts. Do not use switches
that open their contacts using the spring force of the interlock.
When using an interlock mechanism, do not disable the interlock mechanism.
Considering the stopping distance
During operation, the Manipulator cannot stop immediately even if the safeguard is opened. Also, the stopping time and
movement distance vary depending on the following factors.
Hand weight, WEIGHT setting, ACCEL setting, workpiece weight, SPEED setting, movement posture, etc.
For the stopping time and movement distance of the Manipulator, refer to the following section.
Appendix C: Stopping Time and Stopping Distance When Safeguard is Open
Precautions for safeguard operation
Do not open the safeguard unnecessarily while the motor is energized. Frequent safeguard inputs will reduce the life of the
relay.
Normal relay lifespan: About 20,000 times
3.1.6 How to Move Arms with the Electromagnetic Brake
There are two methods to release the electromagnetic brake. Follow either method to release the electromagnetic brake and
move the arms manually.
When using a brake release unit
Follow the method when you just unpack the delivered boxes or when the Controller does not start up yet.
When using software
Follow the method when you can use the software.
While the electromagnetic brake is on (such as in emergency mode), you cannot move any arm by pushing manually.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
85
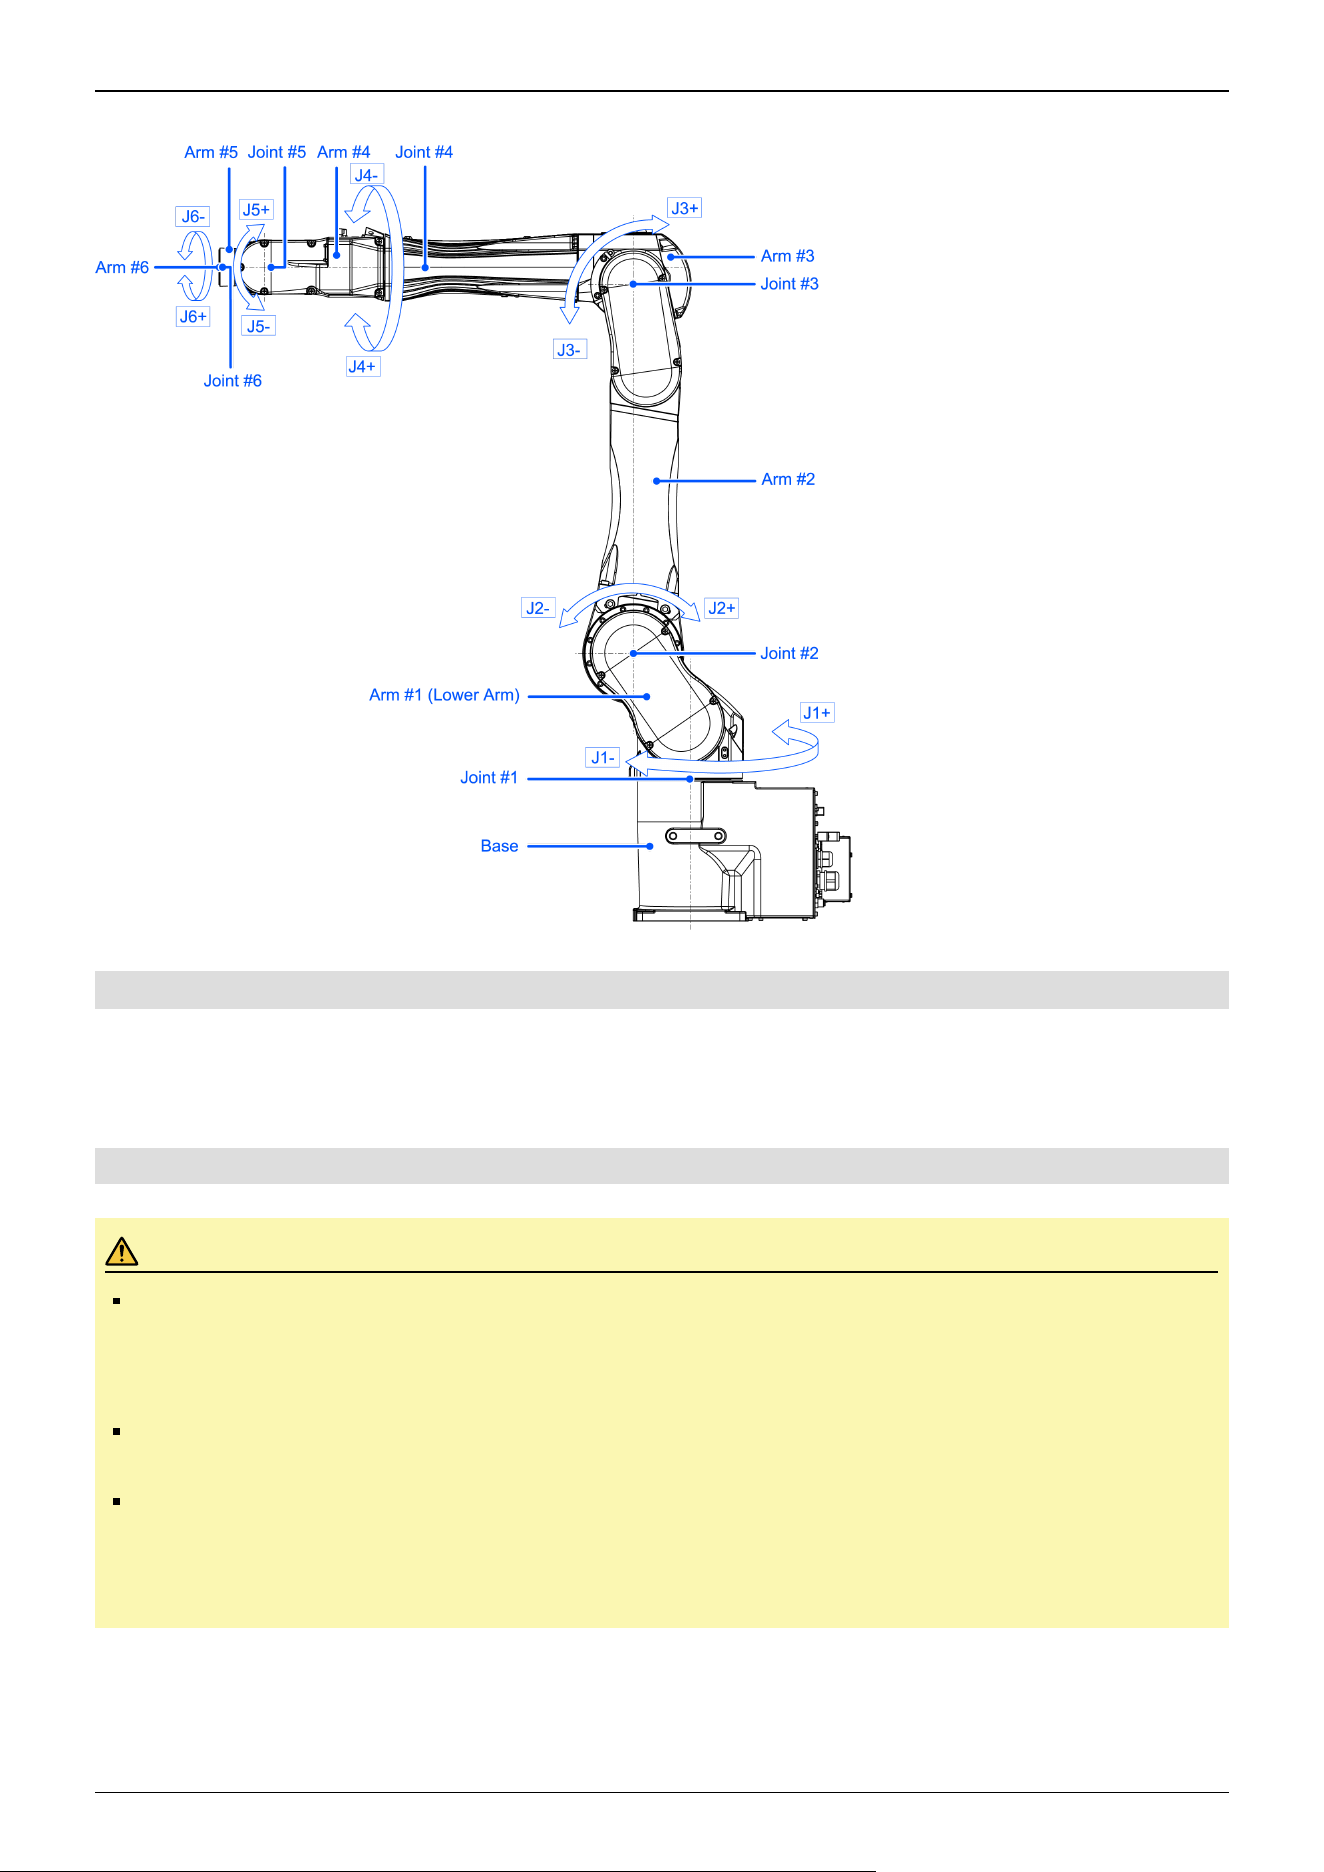
Arm Motion
3.1.6.1 When using a brake release unit
This series has the Brake Release Unit as an option. For details, refer to the following section.
Options
3.1.6.2 When using software
CAUTION
Normally, release the brakes of joints one at a time. If the brakes of two or more joints must be released
simultaneously due to unavoidable reasons, use extreme care. Releasing the brakes of multiple joints
simultaneously may cause the arm to fall in an unexpected direction, resulting in hands or fingers getting
caught or damage or failure of the Manipulator.
After releasing the brake, the arm may fall by its own weight or move to the unexpected direction. Make sure
to prepare a countermeasure to prevent the arm from falling and check the operation environment is safe.
Before releasing the brake, be sure to keep the emergency stop switch in an easily accessible location so that
you can immediately press it if necessary. Otherwise, if the emergency stop switch is not easily accessible,
you will be unable to immediately stop the arm falling due to an erroneous operation, which could lead to
Manipulator damage or breakdown.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
86
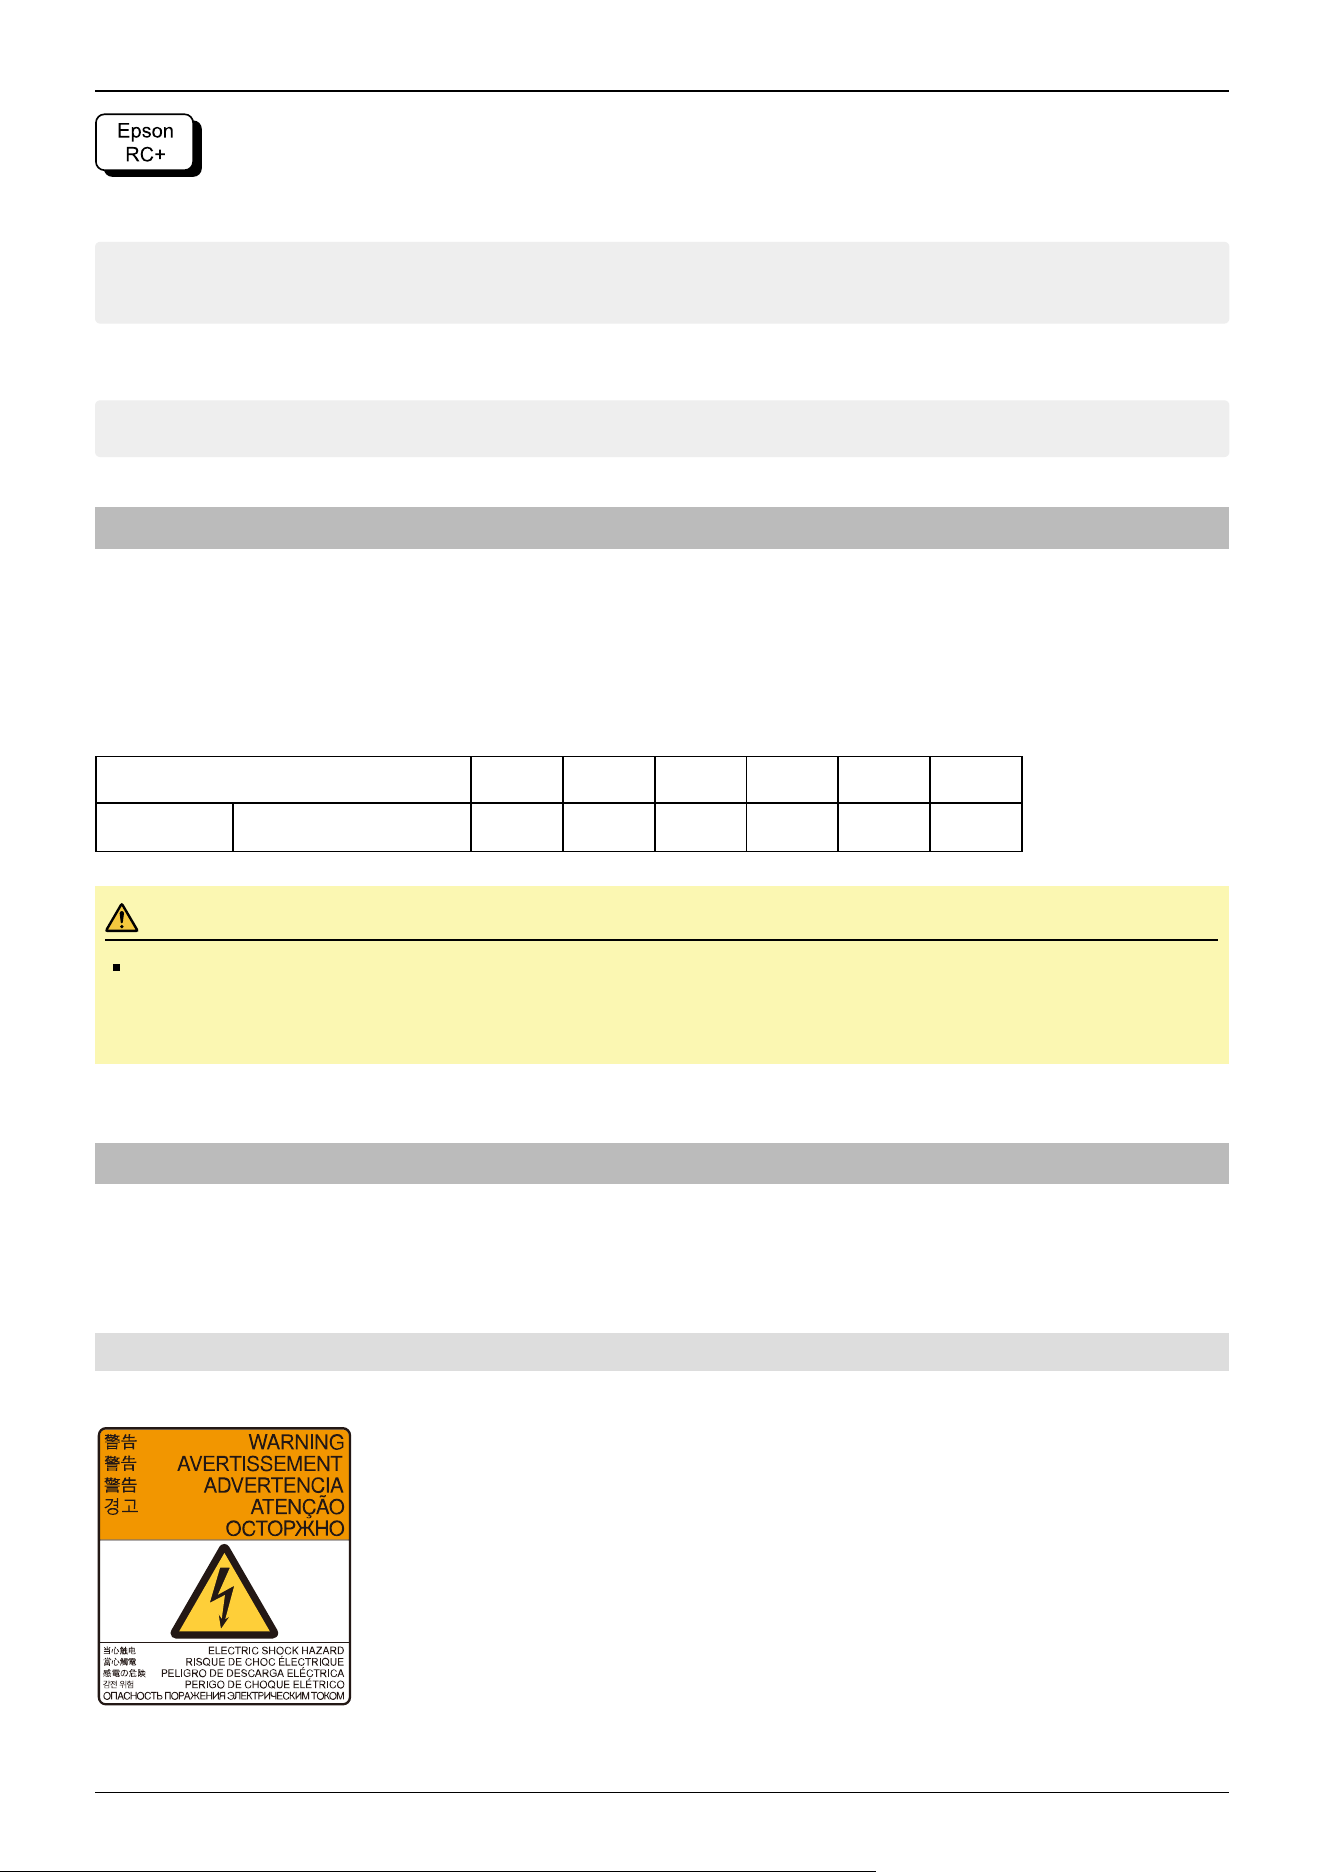
After releasing the Emergency Stop switch, execute the following command in [Command Window].
>Reset
>Brake Off,[The number (from 1 to 6) corresponding to the arm whose brake will be
turned off]
Execute the following command to turn on the brake again.
>Brake On,[The number (from 1 to 6) corresponding to the arm whose brake will be
turned on]
3.1.7 Precaution for Operation in Low Power Status
In the low power status, the Manipulator operates at low speed and low torque. However, comparatively high torque as shown
in the table below may be generated to support the Manipulator’s own weight. Carefully operate the Manipulator since it may
get your hands or fingers caught during operation. The Manipulator may also collide with peripheral equipment and cause
equipment damage to or malfunction of the Manipulator.
Maximum Joint Torque in Low Power Status [Unit: N·m]
Joint #1 #2 #3 #4 #5 #6
Joint Torque C12-C1401** (C12XL) 573.06 517.66 256.9 57.45 53.44 23.94
CAUTION
Carefully operate the Manipulator in the low power status. A comparatively high joint torque may be
generated. It may cause your hands and fingers caught and/or cause equipment damage to or malfunction of
the Manipulator as it may collide with peripheral equipment.
3.1.8 Warning Labels
The Manipulator has the following warning labels. Specific hazards exist in the vicinity of areas with the warning labels. Be
thoroughly careful in handling. To ensure that the Manipulator is operated and maintained safely, be sure to follow the safety
information and warnings indicated on the warning labels. Also, do not tear, damage, or remove these warning labels.
3.1.8.1 Warning Labels
A
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
87
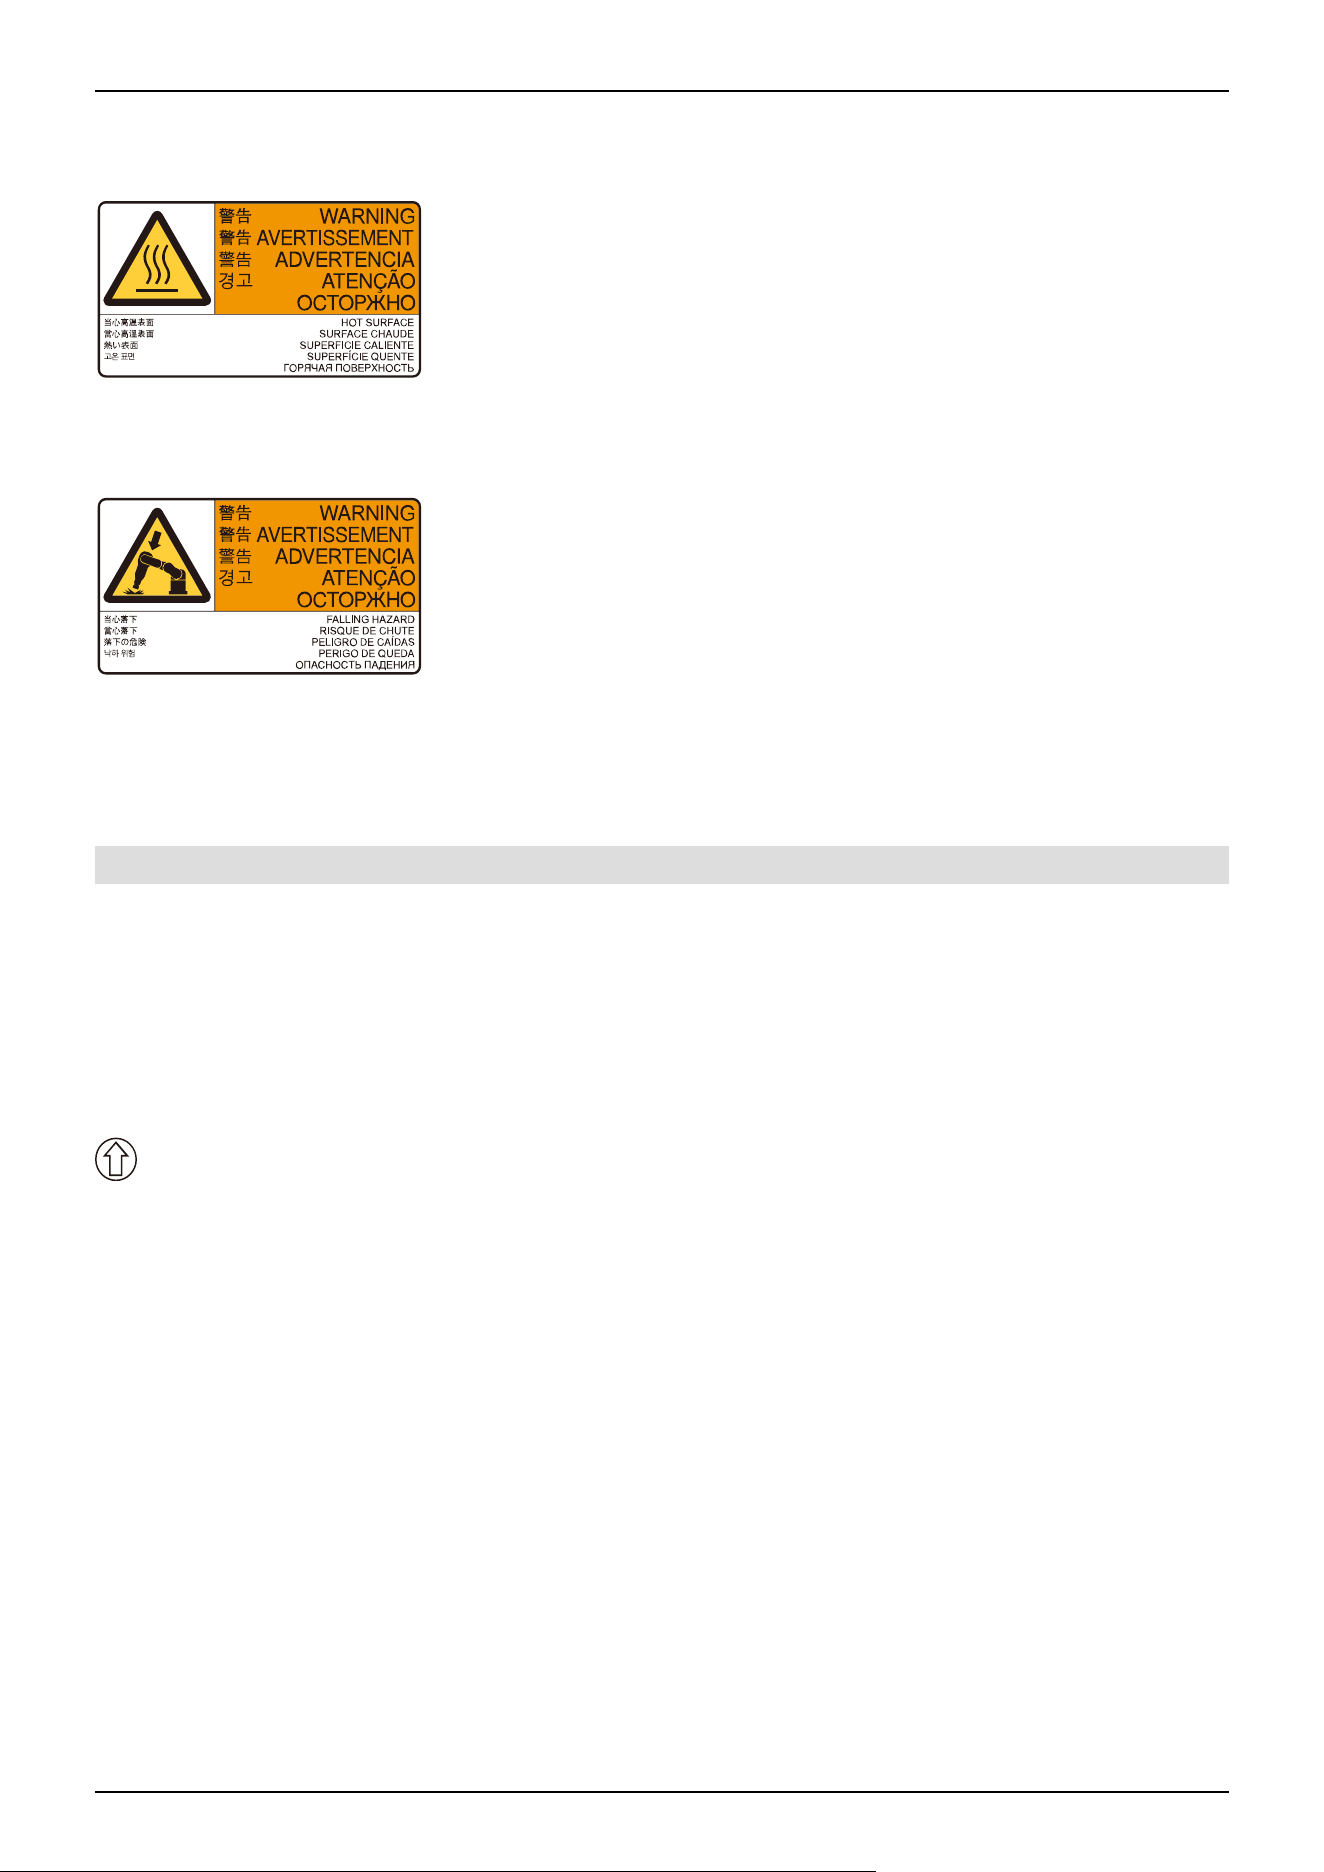
Touching any internal electrified parts while the power is turned on may cause electric shock.
B
HOT Be careful not to burn yourself.
C
When releasing the brakes, be careful of the arm falling due to its own weight.
This warning label is attached on the Manipulator and optional brake release unit as well.
3.1.8.2 Information Labels
1
This indicates the product name, model name, serial number, information of supported laws and regulations, product
specifications (Weight, MAX.REACH, MAX.PAYLOAD, AIR PRESSURE, Motor Power), Main document No.,
manufacturer, importer, date of manufacture, country of manufacture, and the like.
For details, see the label affixed to the product.
2
This indicates the position for mounting eyebolts. Refer to the following section for examples of using eyebolts.
Environment and Installation
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
88
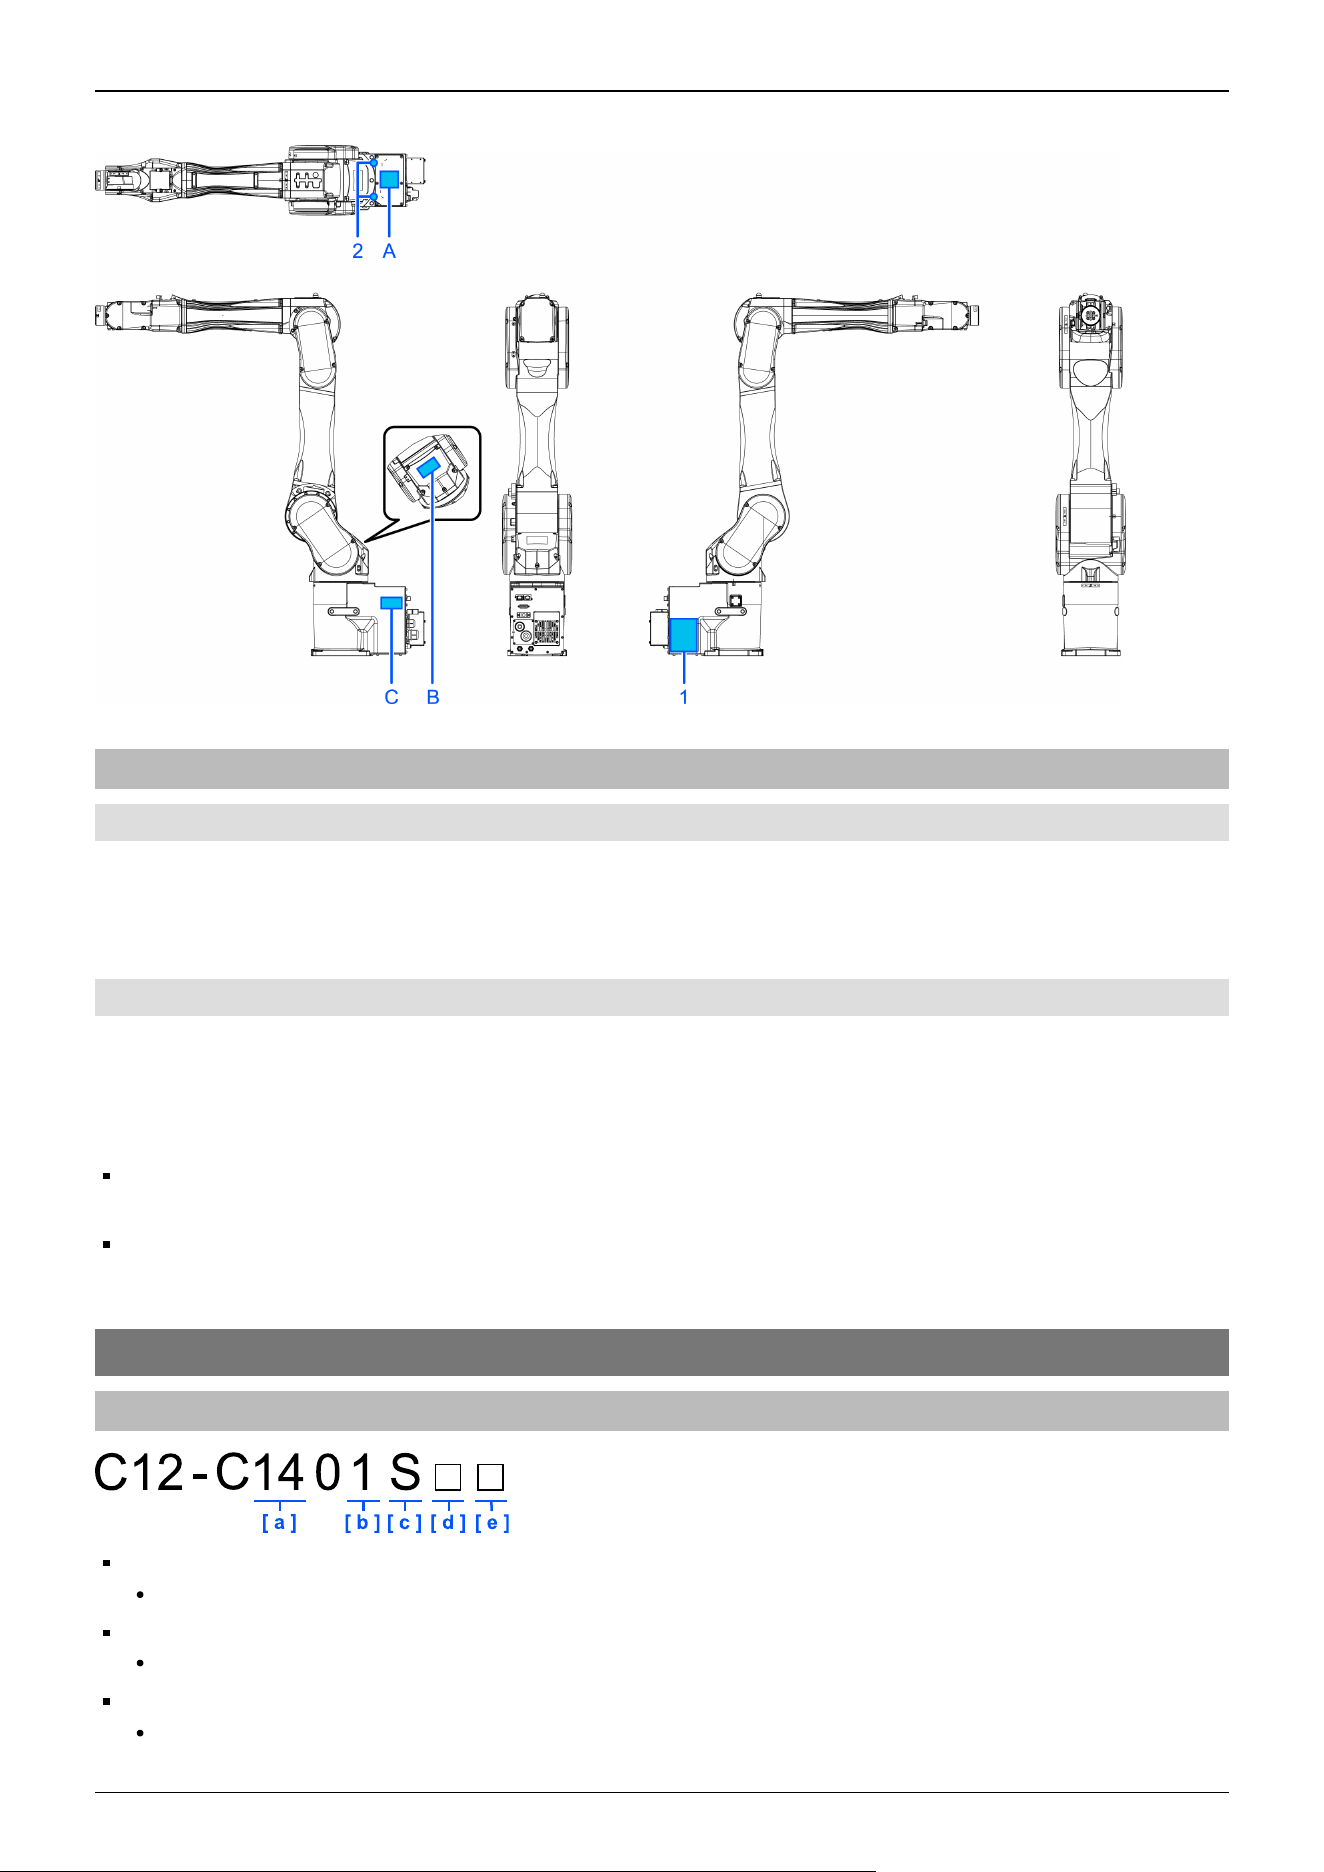
Location of Labels
3.1.9 Responses for Emergencies or Malfunctions
3.1.9.1 When a Collision with the Manipulator Occurs
If the Manipulator has collided with a mechanical stop, peripheral device, or other object, discontinue use and contact the
supplier.
3.1.9.2 Entanglement with the Manipulator
When the operator is caught between the Manipulator and a mechanical part such as a base table, press the emergency stop
switch to release the brake on the subject arm, and then move the arm by hand.
How to release a brake
When using a brake release unit, refer to the following section.
Brake Release Unit
When using software, refer to the following section.
When using software
3.2 Specifications
3.2.1 Model Number
a: Arm length
14: 1400 mm
b: Brake equipment
1: Brakes on all joints
c: Environment
S: Standard *1
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
89
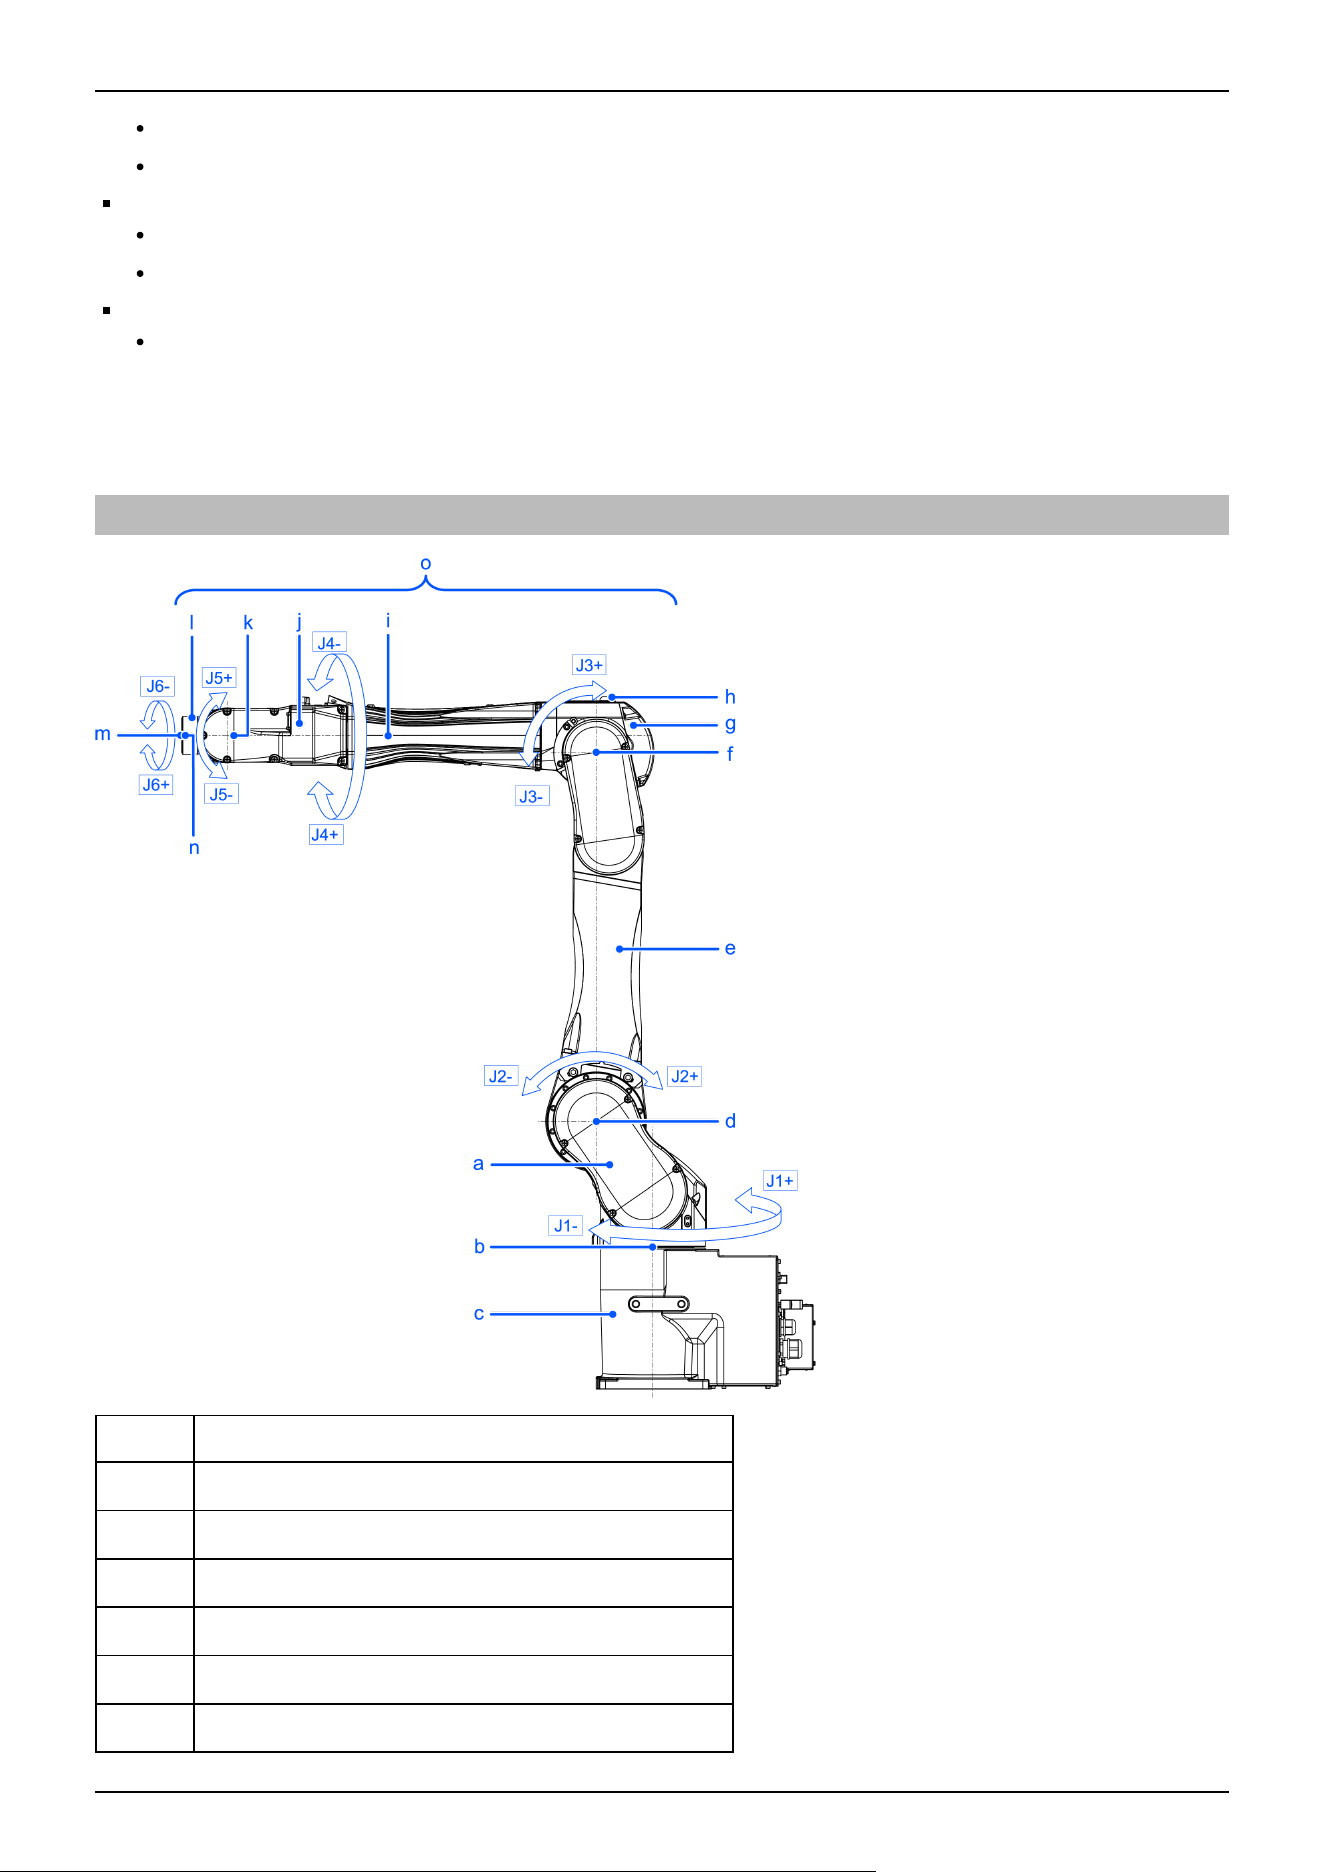
C: Cleanroom & ESD (anti-static) *1
P: Protection *2
d: M/C cable installation direction
□: Cable backward
B: Cable downward
e: Mounting type
□: Table top mounting
*1 Equivalent to IP20
*2 IP67 (fan cover: equivalent to IP20)
3.2.2 Part Names and Motion Range of Each Arm
Symbol Description
a Arm #1 (Lower Arm)
b Joint #1 (The whole Manipulator revolves.)
c Base
d Joint #2 (The lower arm swings.)
e Arm #2
f Joint #3 (The upper arm swings.)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
90
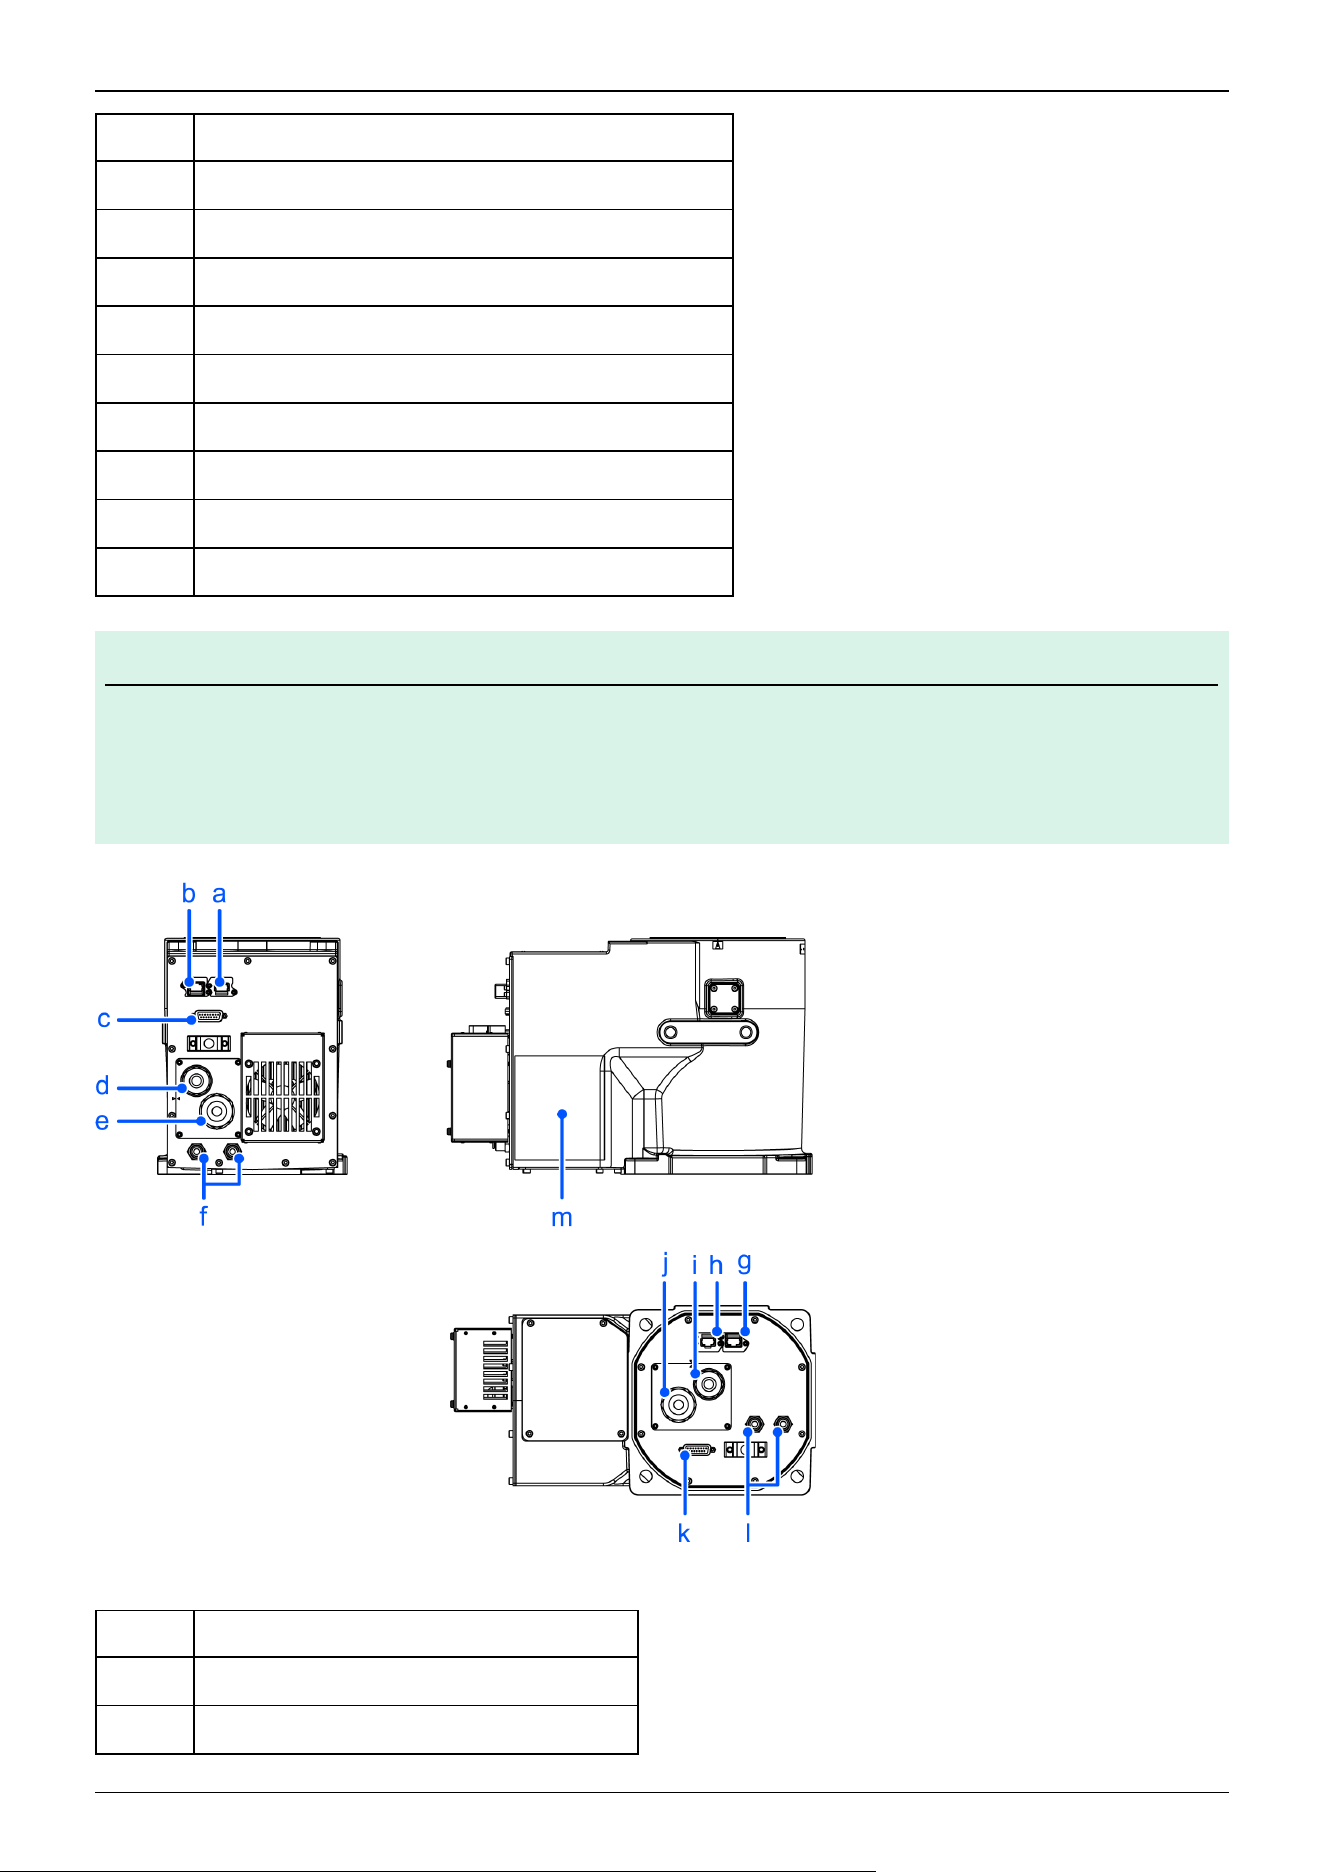
Symbol Description
g Arm #3
h LED Lamp (This lamp lights up while the motors are on.)
i Joint #4 (The wrist revolves.)
j Arm #4
k Joint #5 (The wrist swings.)
l Arm #5
m Arm #6
n Joint #6 (The hand rotates.)
o Upper Arm (Arms #3 to #6)
KEY POINTS
When the LED lamp is lighting or the Controller power is on, the current is being applied to the Manipulator. (The
LED lamp may not be seen depending on the Manipulator’s posture. Be thoroughly careful. Performing any work
procedure with the power turned on is extremely dangerous and may result in electric shock and/or malfunction
of the robot system. Before starting any maintenance work, be sure to turn off the Controller.
Cable backward model
Symbol Description
a Ethernet cable connector
b Force Sensor cable connector
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
91
Symbol Description
c User cable connector (15-pin D-sub connector)
d Signal cable
e Power cable
f Fitting for ⌀6 mm tube (Air1, Air2)
Cable downward model
Symbol Description
g Force Sensor cable connector
h Ethernet cable connector
i Signal cable
j Power cable
k User cable connector (15-pin D-sub connector)
l Fitting for ⌀6 mm tube (Air1, Air2)
Cable backward model, Cable downward model
Symbol Description
m Face plate (serial number of Manipulator)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
92
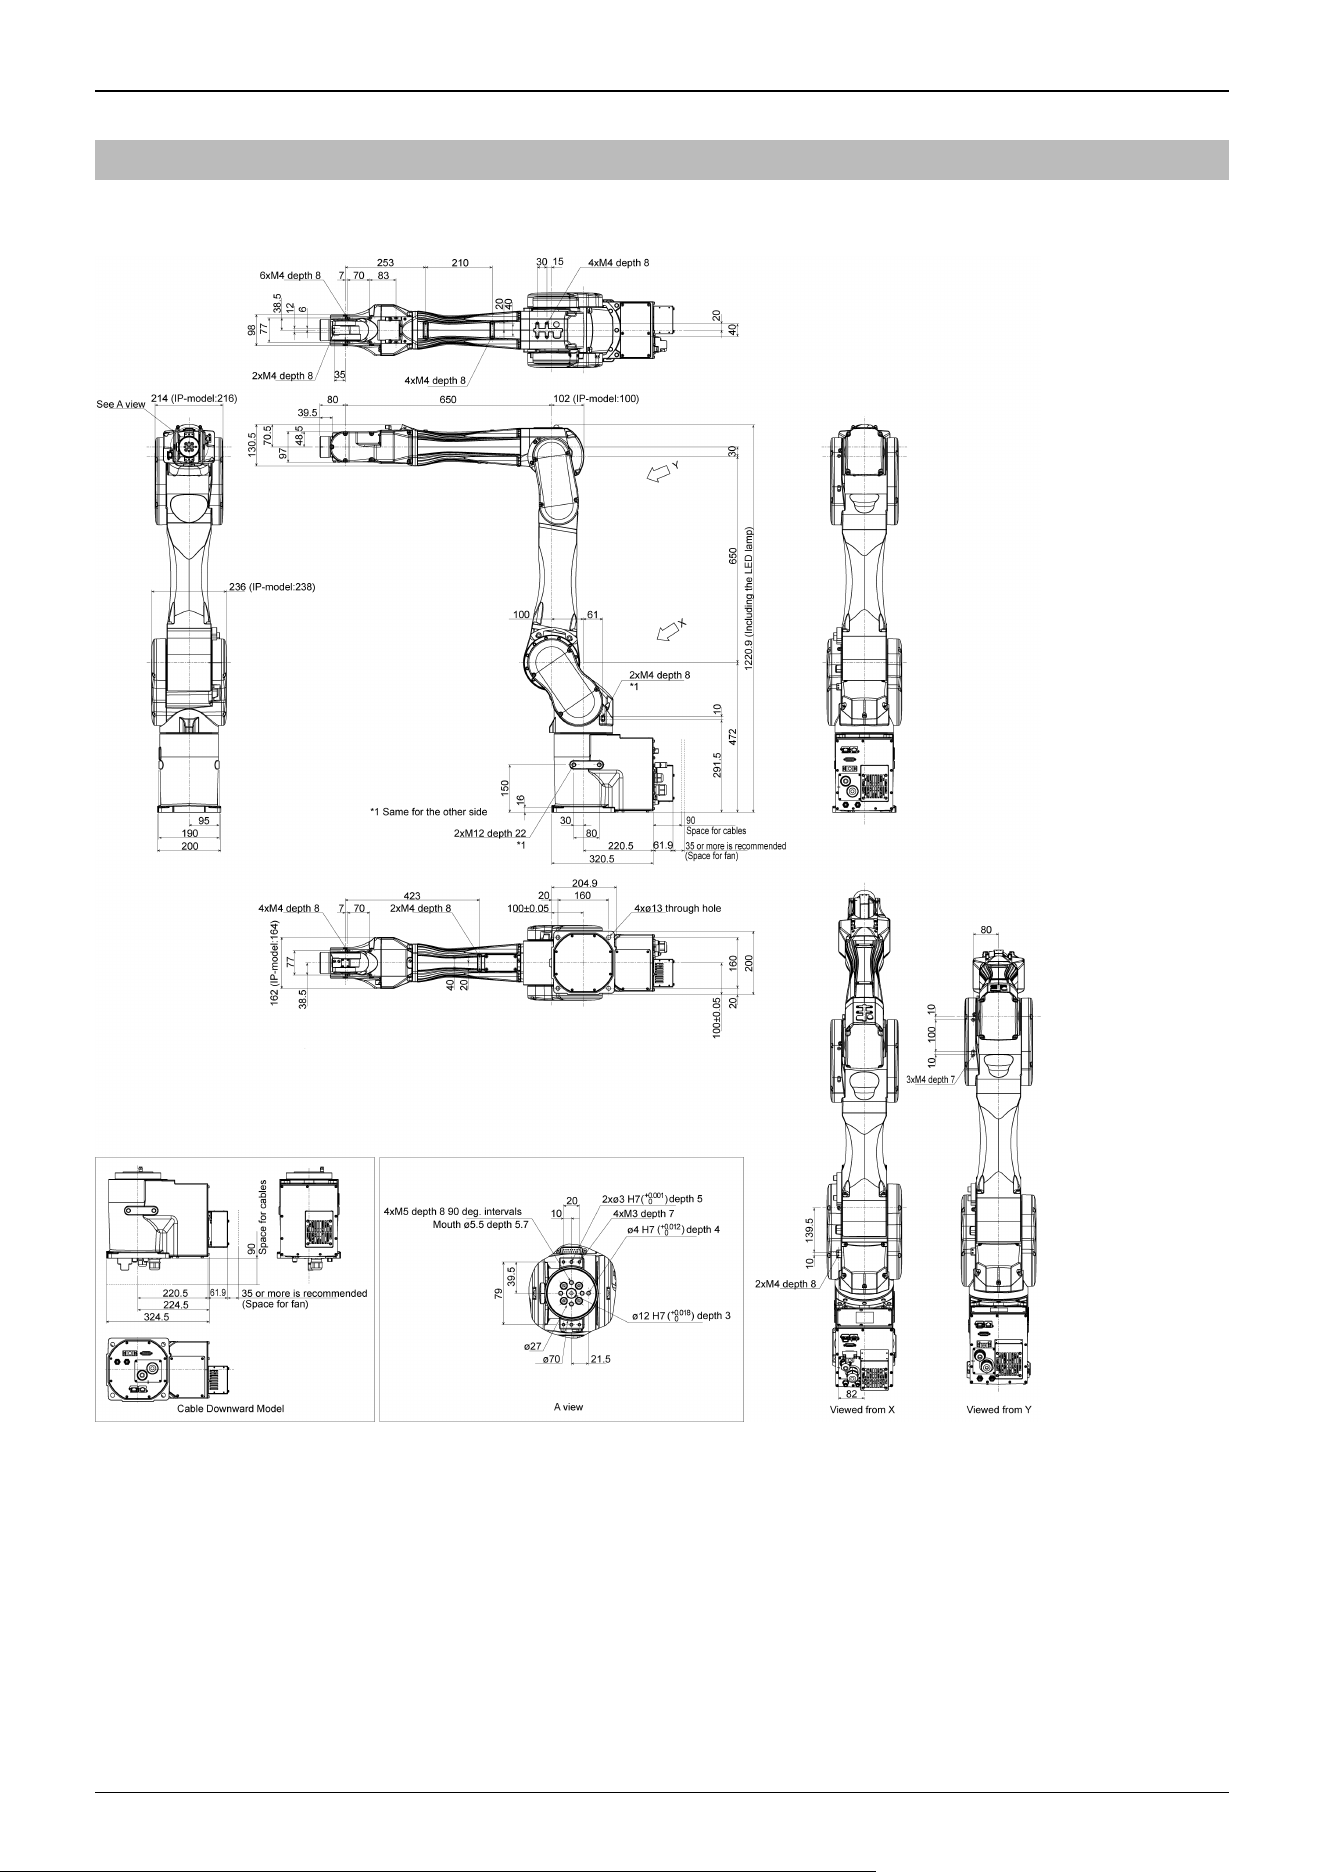
3.2.3 Outer Dimensions
(Units: mm)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
93
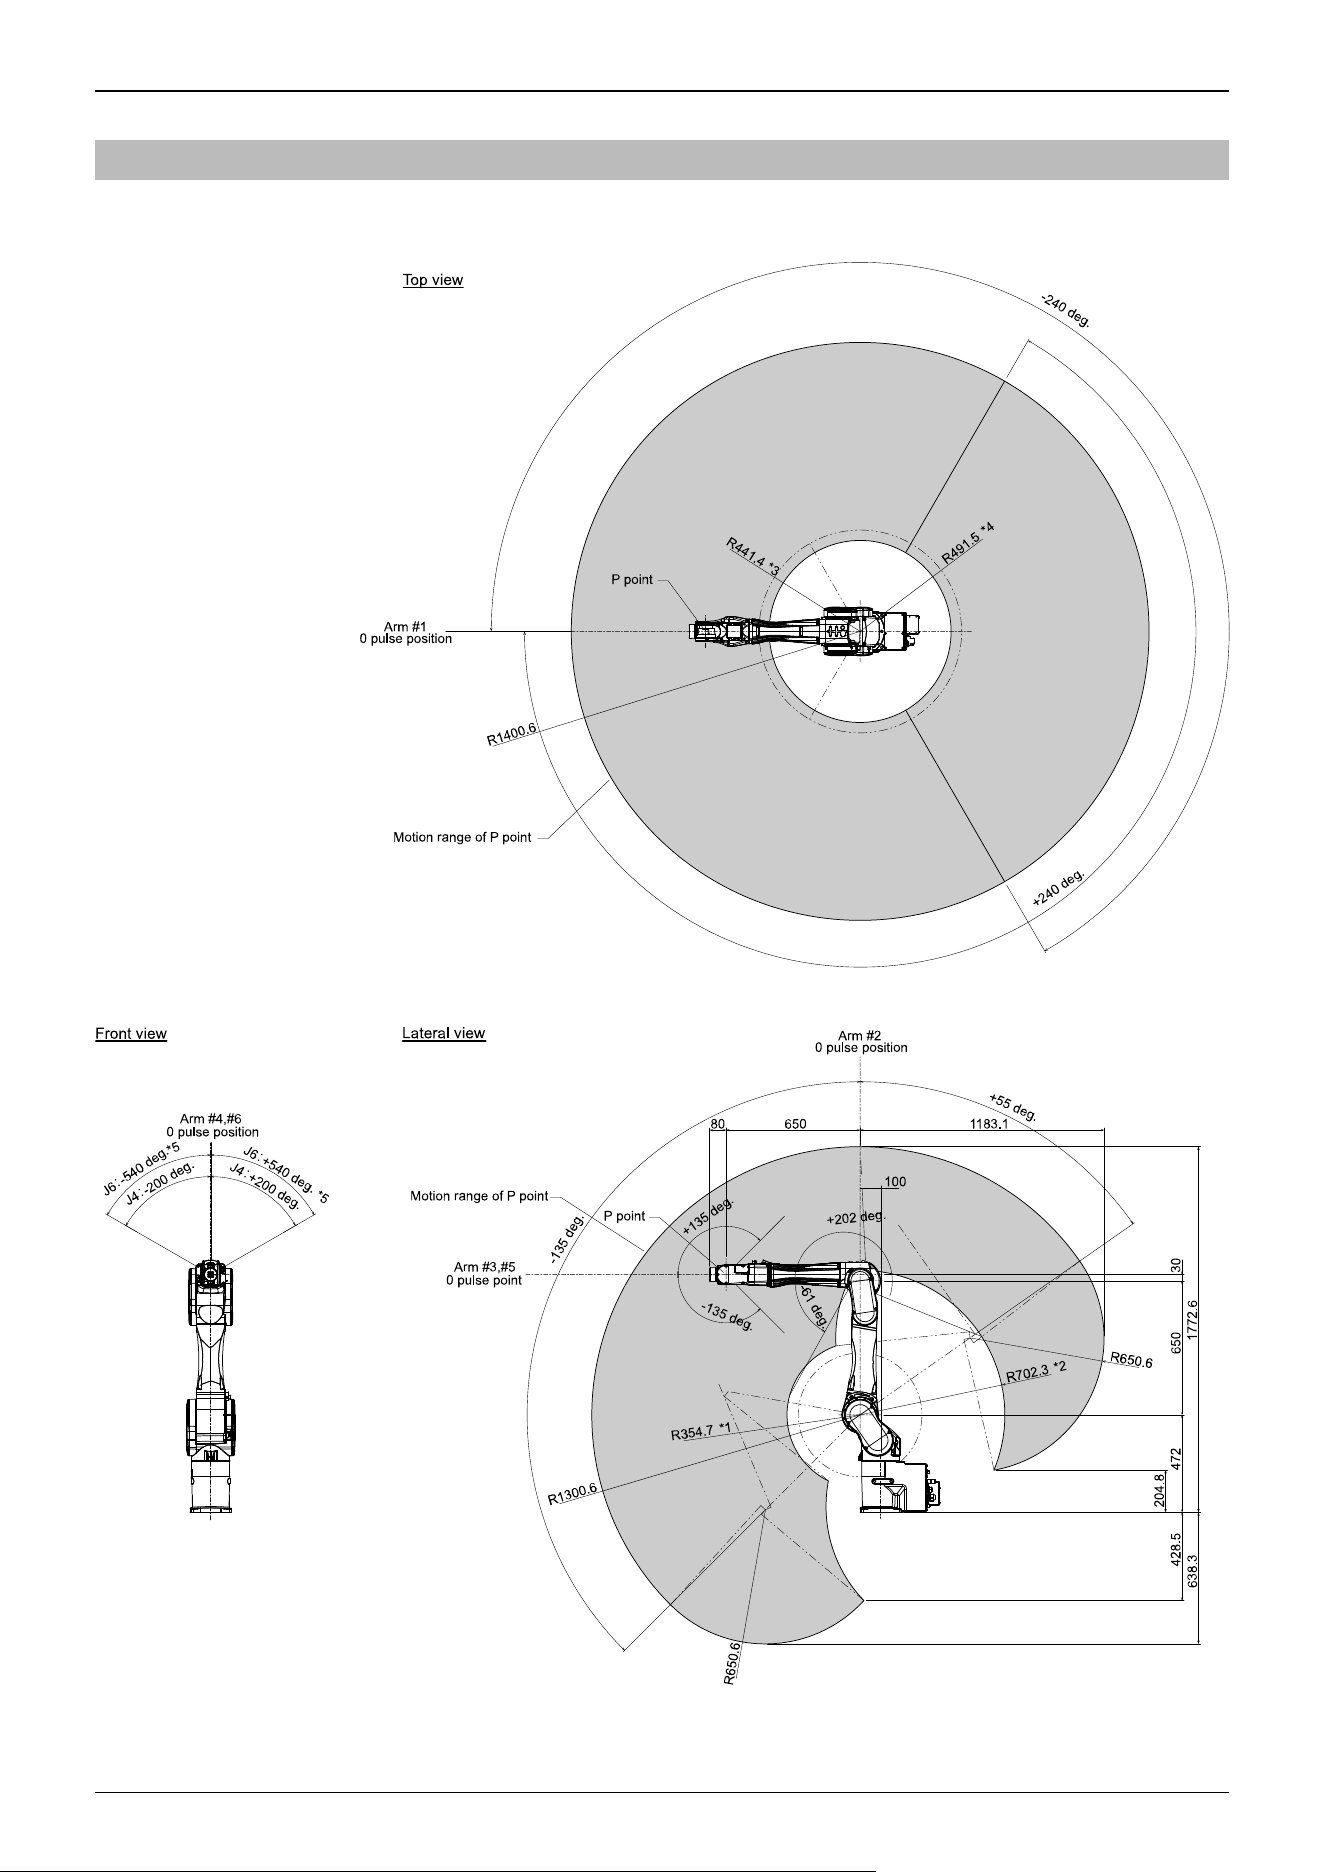
3.2.4 Standard Work Envelope
(Units: mm)
(deg. = °)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
94
*P point: Intersection of the rotation centers for Joint #4, #5, and #6
*1: P point from lateral with Joint #3 declining -61° (Joint #2 center – P point center)
*2: P point from lateral with Joint #3 tilting up +202° (Joint #2 center – P point center)
*3: P point from top with Joint #3 declining -61° (Joint #1 center – P point center)
*4: P point from top with Joint #3 tilting up +202° (Joint #1 center – P point center)
*5: The motion range ±540° of J6 can be changed.For details, refer to the following.
Appendix
CAUTION
Pay attention to the arm pose of the basic arms (Arms #1, #2, and #3) when operating the Manipulator. Arm
#5 moves keeping a constant angle regardless of the arm pose. Depending on the arm pose of the basic
arms, the wrist may collide with the Manipulator. The collision may cause equipment damage to and/or
malfunction of the Manipulator.
3.2.5 Specifications
3.2.5.1 Specifications Table
For the specifications tables of each model, refer to the following section.
C12 Specifications
3.2.5.2 Options
For details, refer to the following section.
Options
3.2.6 How to Set the Model
The Manipulator model for your system has been set before shipment from the factory.
CAUTION
If changing the setting of the Manipulator model, be responsible and absolutely certain that the wrong
Manipulator model is not set. Incorrect setting of the Manipulator model may result in abnormal or no
operation by the Manipulator and could even cause safety problems.
If a custom specifications number (MT***) or (X***) is written on the face plate (serial number label), the Manipulator has
custom specifications.
Models with custom specifications may require a different setting procedure. Check the custom specifications number, and
contact the supplier for more information.
The Manipulator model is set from software. For details, refer to the following manual.
"Epson RC+ User's Guide - Robot Configuration"
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
95
3.3 Environment and Installation
The robot system should be designed and installed by people who have received installation training provided by Epson and
the suppliers. Also, the laws and regulations of the installation country must be followed.
3.3.1 Environment
To ensure that the robot system operates and maintains maximum performance and to ensure its safe use, the robot system
should be installed in an environment that meets the following requirements.
Item Conditions
Ambient temperature *
Installation: 5 to 40°C
Transport, storage: -20 to 60°C
Ambient relative humidity
Installation: 10 to 80% (no condensation)
Transport, storage: 10 to 90% (no condensation)
Fast transient burst noise 1 kV or less (signal line)
Electrostatic noise 4 kV or less
Altitude 1000 m or less
* The ambient temperature requirement is for the Manipulator only. For details on the environment requirements for the
connected Controller, refer to the Robot Controller manual.
KEY POINTS
When used in a low-temperature environment near the minimum temperature specified in the product
specifications, or when the unit is idle for a long period of time during holidays or at night, a collision detection
error or similar error may occur immediately after the start of operation due to high resistance in the drive unit. In
such cases, warm-up operation for about 10 minutes is recommended.
KEY POINTS
If there are conductive objects such as fences or ladders within 2.5 m of the Manipulator, these objects must be
grounded.
Also, depending on the environmental specifications of the Manipulator, the following requirements must be met.
Environmental Specifications Conditions
S, C, P
- Install indoors.
- Keep away from direct sunlight.
- Keep away from shocks or vibrations.
- Keep away from sources of electric noise.
- Keep away from explosive areas.
- Keep away from large quantities of radiation.
S, C
- Keep away from dust, oily smoke, salinity, metal powder, and other contaminants.
- Keep away from flammable or corrosive liquids and gases.
- Keep away from organic solvents, acids, alkalis, and chlorine cutting fluids.
- Keep away from water.
✏
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
96
The following items should also be taken into consideration for the installation environment of Manipulators with protected-
models.
These are compliant with the IP67 protection class (IEC 60529, JIS C0920). The Manipulators can be used in environments
where the possibility of dust, water, and water-soluble cutting oil falling of the Manipulator exists.
They can be installed in environments where dust, oil smoke, metal powder, and similar substances are airborne, but they
are not suitable for use with nitrile rubber oil seals, O-rings, packings, liquid gaskets, or other substances that impair
sealing performance.
The Manipulator cannot be used in environments exposed to liquids or airborne droplets that are corrosive such as acids or
alkalis.
In environments that are exposed to airborne droplets containing salt, rust may also form on the Manipulator.
Manipulator surfaces are generally oil-resistant, but if special oils are to be used, oil resistance should be checked before
use. For more information, please contact the supplier.
In environments with rapid changes in temperature and humidity, condensation may form inside the Manipulator.
When handling food directly, it is necessary to make sure that the Manipulator is not likely to contaminate the food. For
more information, please contact the supplier.
The Controllers used with Manipulators with protected-models do not have protection against harsh environments. The
Controller should be installed in a location that meets its operating environment requirements.
KEY POINTS
If the Manipulator will be used in a location that does not meet the above requirements, please contact the
supplier.
WARNING
Always use a circuit breaker for the Controller's power supply. Failure to use a circuit breaker may result in an
electrical shock hazard or malfunction due to an electrical leakage. Select the correct circuit breaker based on
the Controller that you are using. For details, refer to the following manual.
"Robot Controller Manual"
CAUTION
When cleaning the Manipulator, do not rub it strongly with alcohol or benzene. Coated surfaces may lose their
luster.
3.3.2 Manipulator Mounting Dimensions
Mounting Area
Also, besides the area required for installation of the Manipulator, Controller, peripheral equipment, and other devices, the
following space should be provided at a minimum.
Space for teaching
Space for maintenance and inspections (for installing jigs and working safely within the safety barriers)
Space for cables
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
97
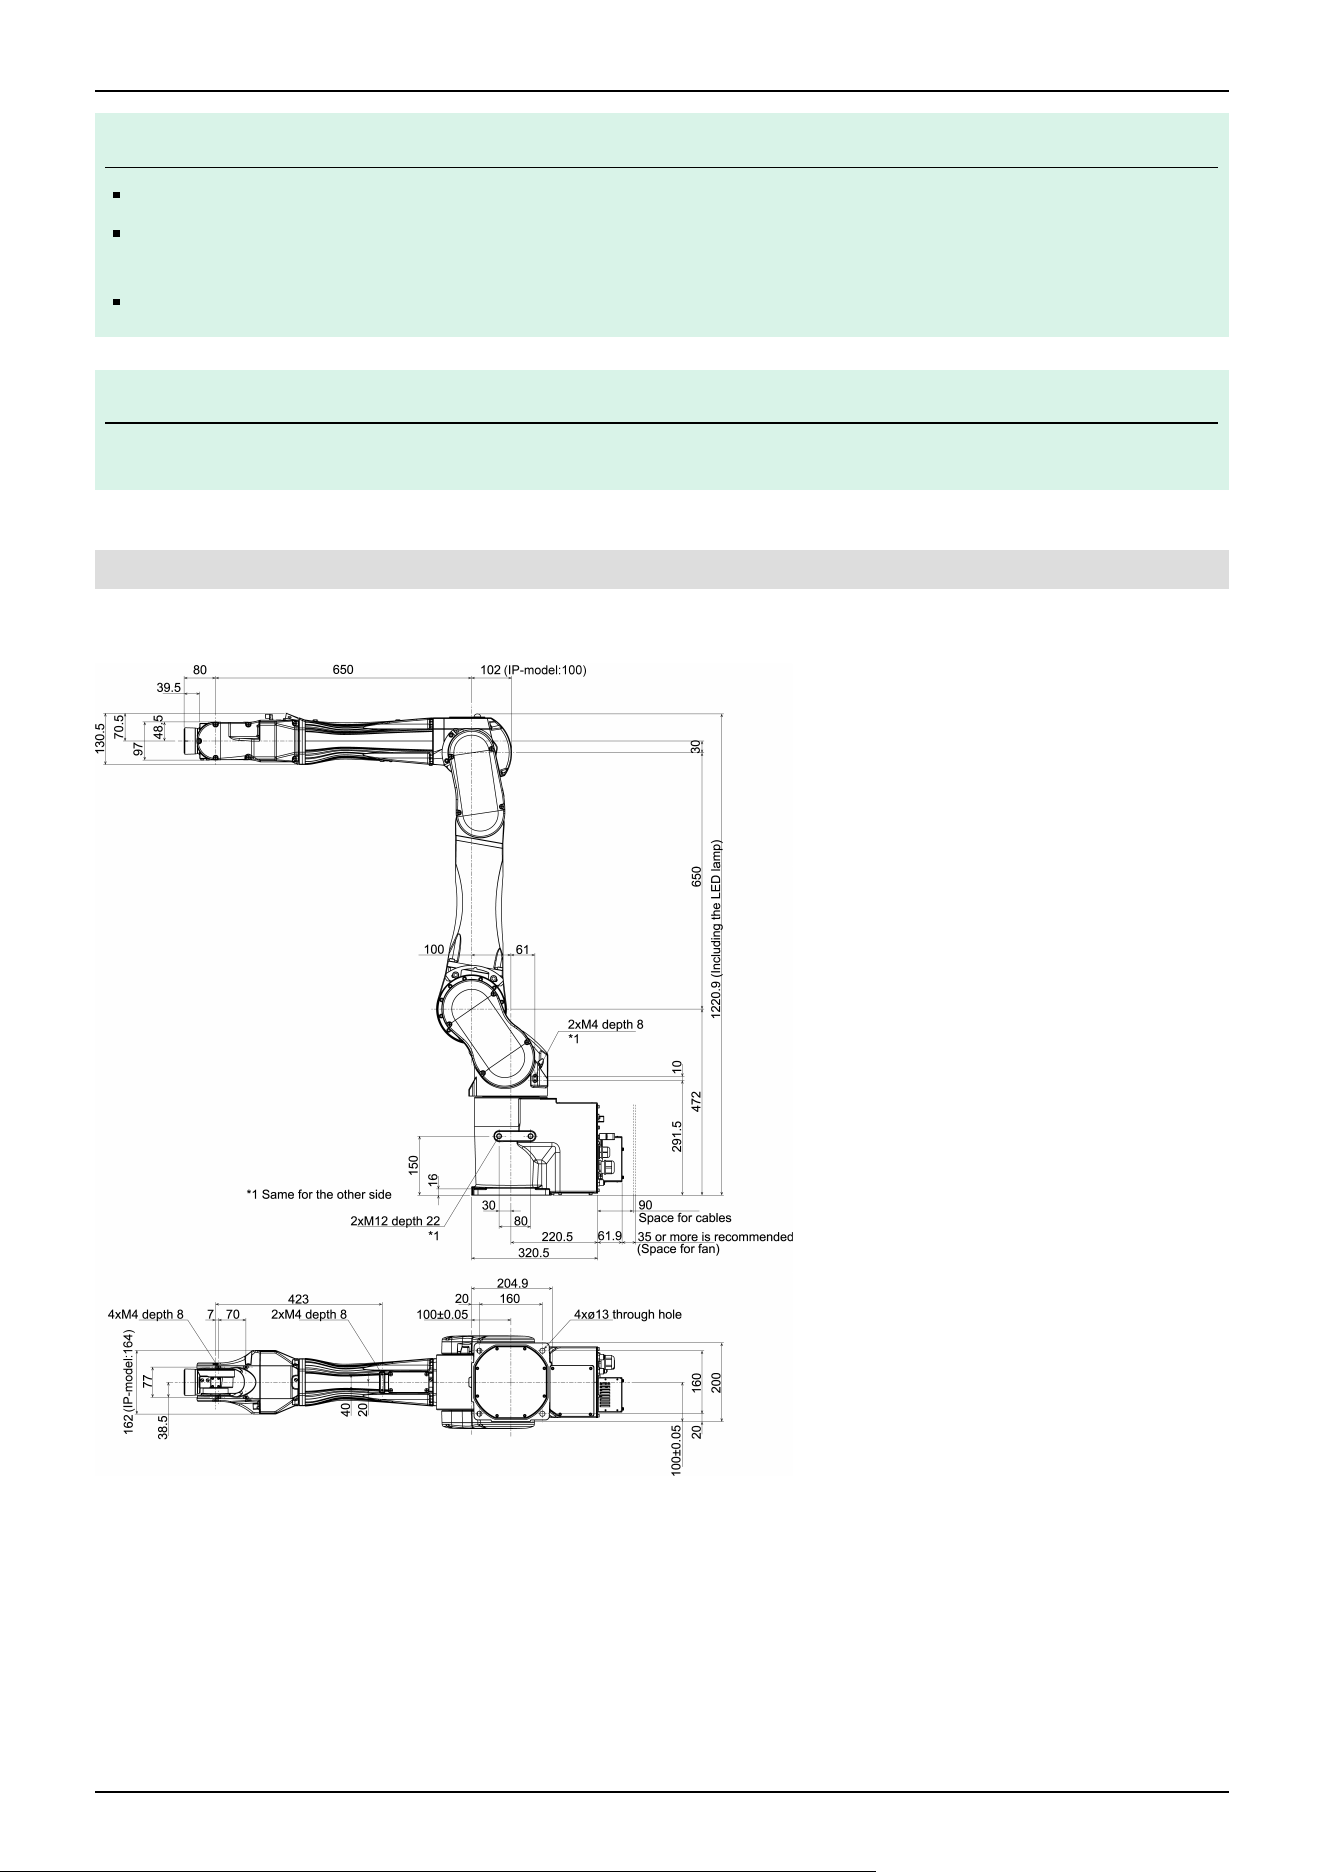
KEY POINTS
When installing the cables, be sure to maintain sufficient distance from obstacles.
For the minimum bend radius of the M/C cable, refer to the following section.
C12 Specifications
Also, leave enough space for other cables so that they are not forced to bend at extreme angles.
KEY POINTS
Make sure to leave 35 mm or more space around the fan cover.
3.3.2.1 Cable backward model
(Units: mm)
depth = depth of threaded hole
✏
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
98
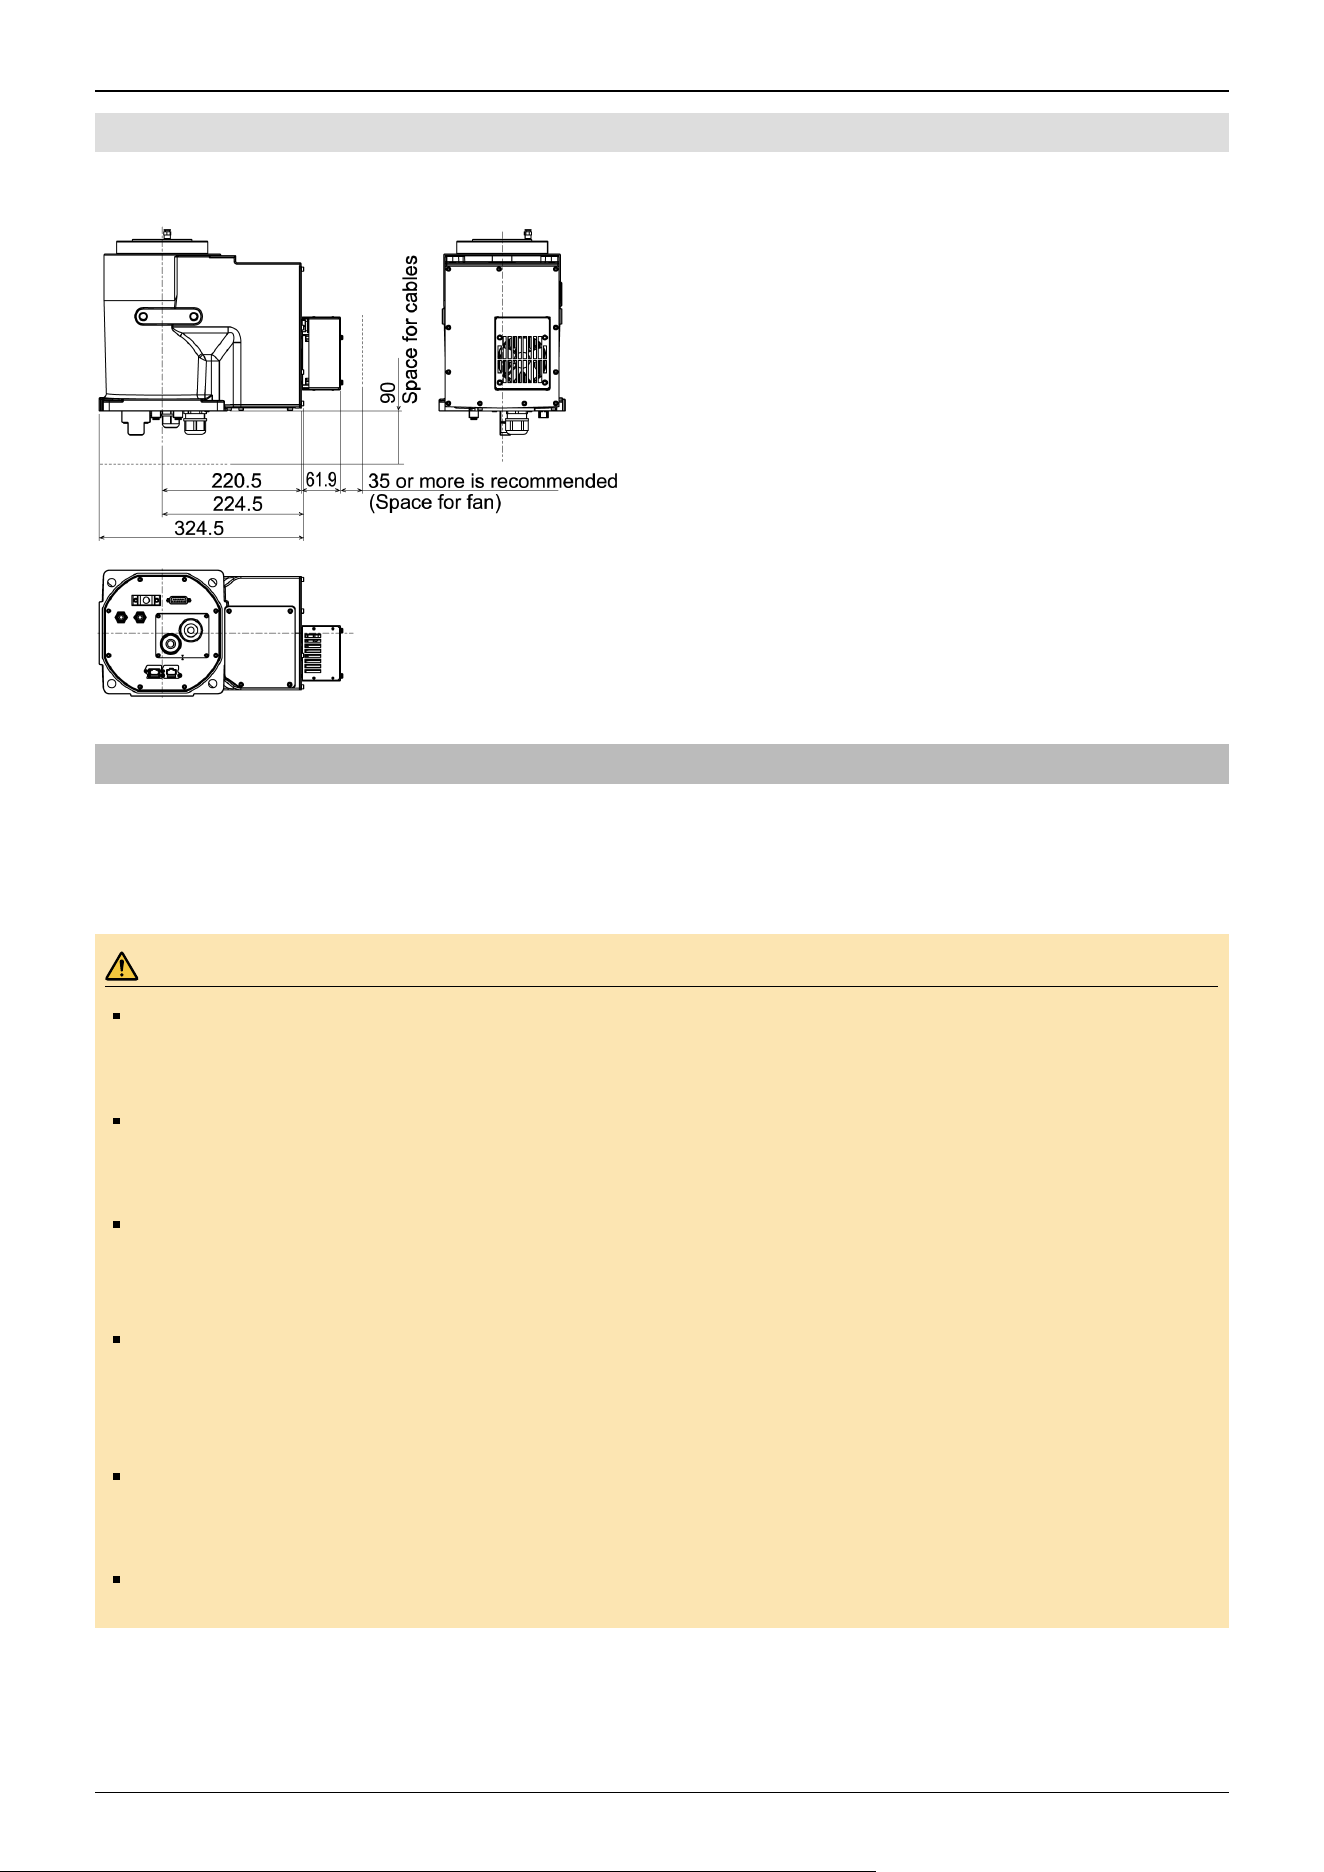
3.3.2.2 Cable downward model
The following part differs from the cable backward model.
3.3.3 From Unpacking to Installation
Transportation and installation of the Manipulator and related equipment should be performed by people who have received
installation training provided by Epson and the suppliers. Also, the laws and regulations of the installation country must be
followed.
WARNING
Only qualified personnel should perform sling work and operate a crane or a forklift. When these operations
are performed by unqualified personnel, it is extremely hazardous and may result in serious bodily injury
and/or severe equipment damage to the robot system
When hoisting the Manipulator, use your hands to balance it. Losing balance may cause the Manipulator to
drop, which is extremely hazardous and may result in serious injury and/or severe damage to the robot
system.
To ensure safety, be sure to install safeguards for the robot system. For more information on safeguards, refer
to the following manual.
"Epson RC+ User’s Guide - Safety - Installation and Design Precautions "
Install the Manipulator in a location with sufficient space so that a tool or a work piece does not touch a wall or
a safeguard when the Manipulator extends its arm fully while holding a work piece. If the tool or the workpiece
tip reaches a wall or safeguards, it is extremely hazardous and may result in serious bodily injury and/or
severe equipment damage to the robot system.
Be sure to anchor the Manipulator before turning on the power or operating it. Turning on the power or
operating the Manipulator while it is not anchored may cause the Manipulator to fall over, which is extremely
hazardous and may result in serious injury and/or severe damage to the robot system.
Before installing or operating the Manipulator, make sure that no parts of the Manipulator are missing and that
it has no damage or other external defects. Missing parts or damage may cause malfunction of the
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
99
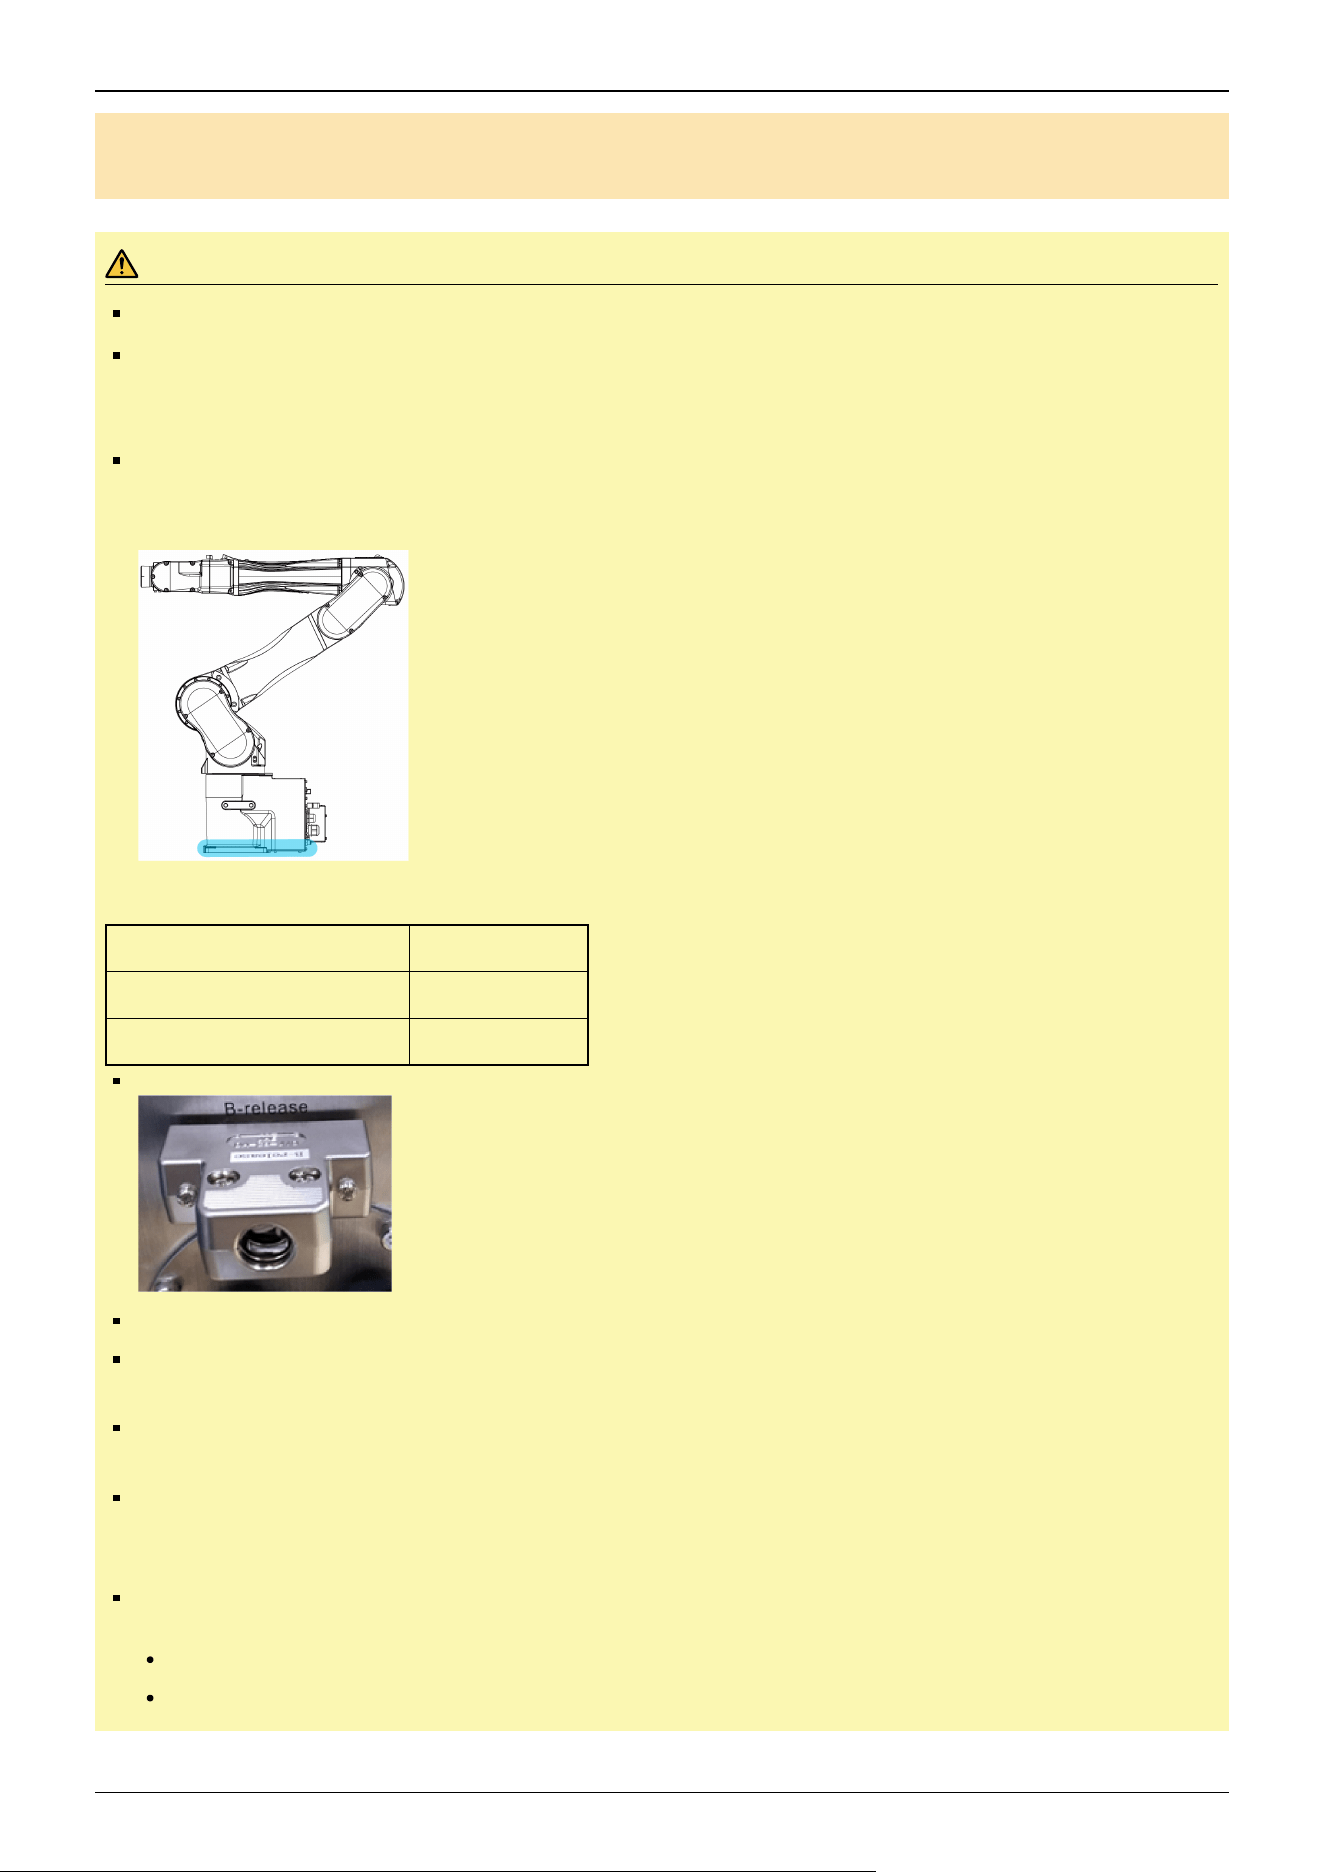
Manipulator, is extremely hazardous, and may result in serious injury and/or severe equipment damage to the
robot system.
CAUTION
Use a cart or the like to transport the Manipulator in the same status as it was delivered.
When removing the fixing bolts securing the Manipulator to the transportation pallet and the packing box or
the anchor bolts, support the Manipulator to prevent it falling. Removing the fixing bolts or anchor bolts
without supporting the Manipulator may cause it to fall, catching your hands or feet.
The Manipulator should be transported by two or more people or secured to transporting equipment. Also, do
not hold the bottom of the base (the screened parts in the figure). Holding these parts by hand is extremely
hazardous and may cause your hands and fingers caught.
Manipulator weight
C12-C1401S***
Standard, Cleanroom Model 63 kg: 139 lb
Protected-Model 67 kg: 148 lb
Take extra care when transporting the Manipulator. You may hit and damage the connector.
During unpacking and relocation, avoid applying external force to the arms and motors of the Manipulator.
When transporting the Manipulator over long distances, secure it directly to transporting equipment so that it
will not fall. If necessary, pack the Manipulator using the same packaging as delivery.
The Manipulator must be installed to avoid interference with surrounding buildings, structures, and other
machines and equipment that may create a trapping hazard or pinch points.
Resonance (resonating sound or minute vibrations) may occur during Manipulator operation depending on
the rigidity of the base table. If the resonance occurs, improve the rigidity of the base table or change the
speed or acceleration and deceleration settings of the Manipulator.
Manipulator base has a cooling fan. Install the Manipulator not to seal the cooling fan. For details, refer to the
following figure.
Cable backward model
Cable downward model
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
100
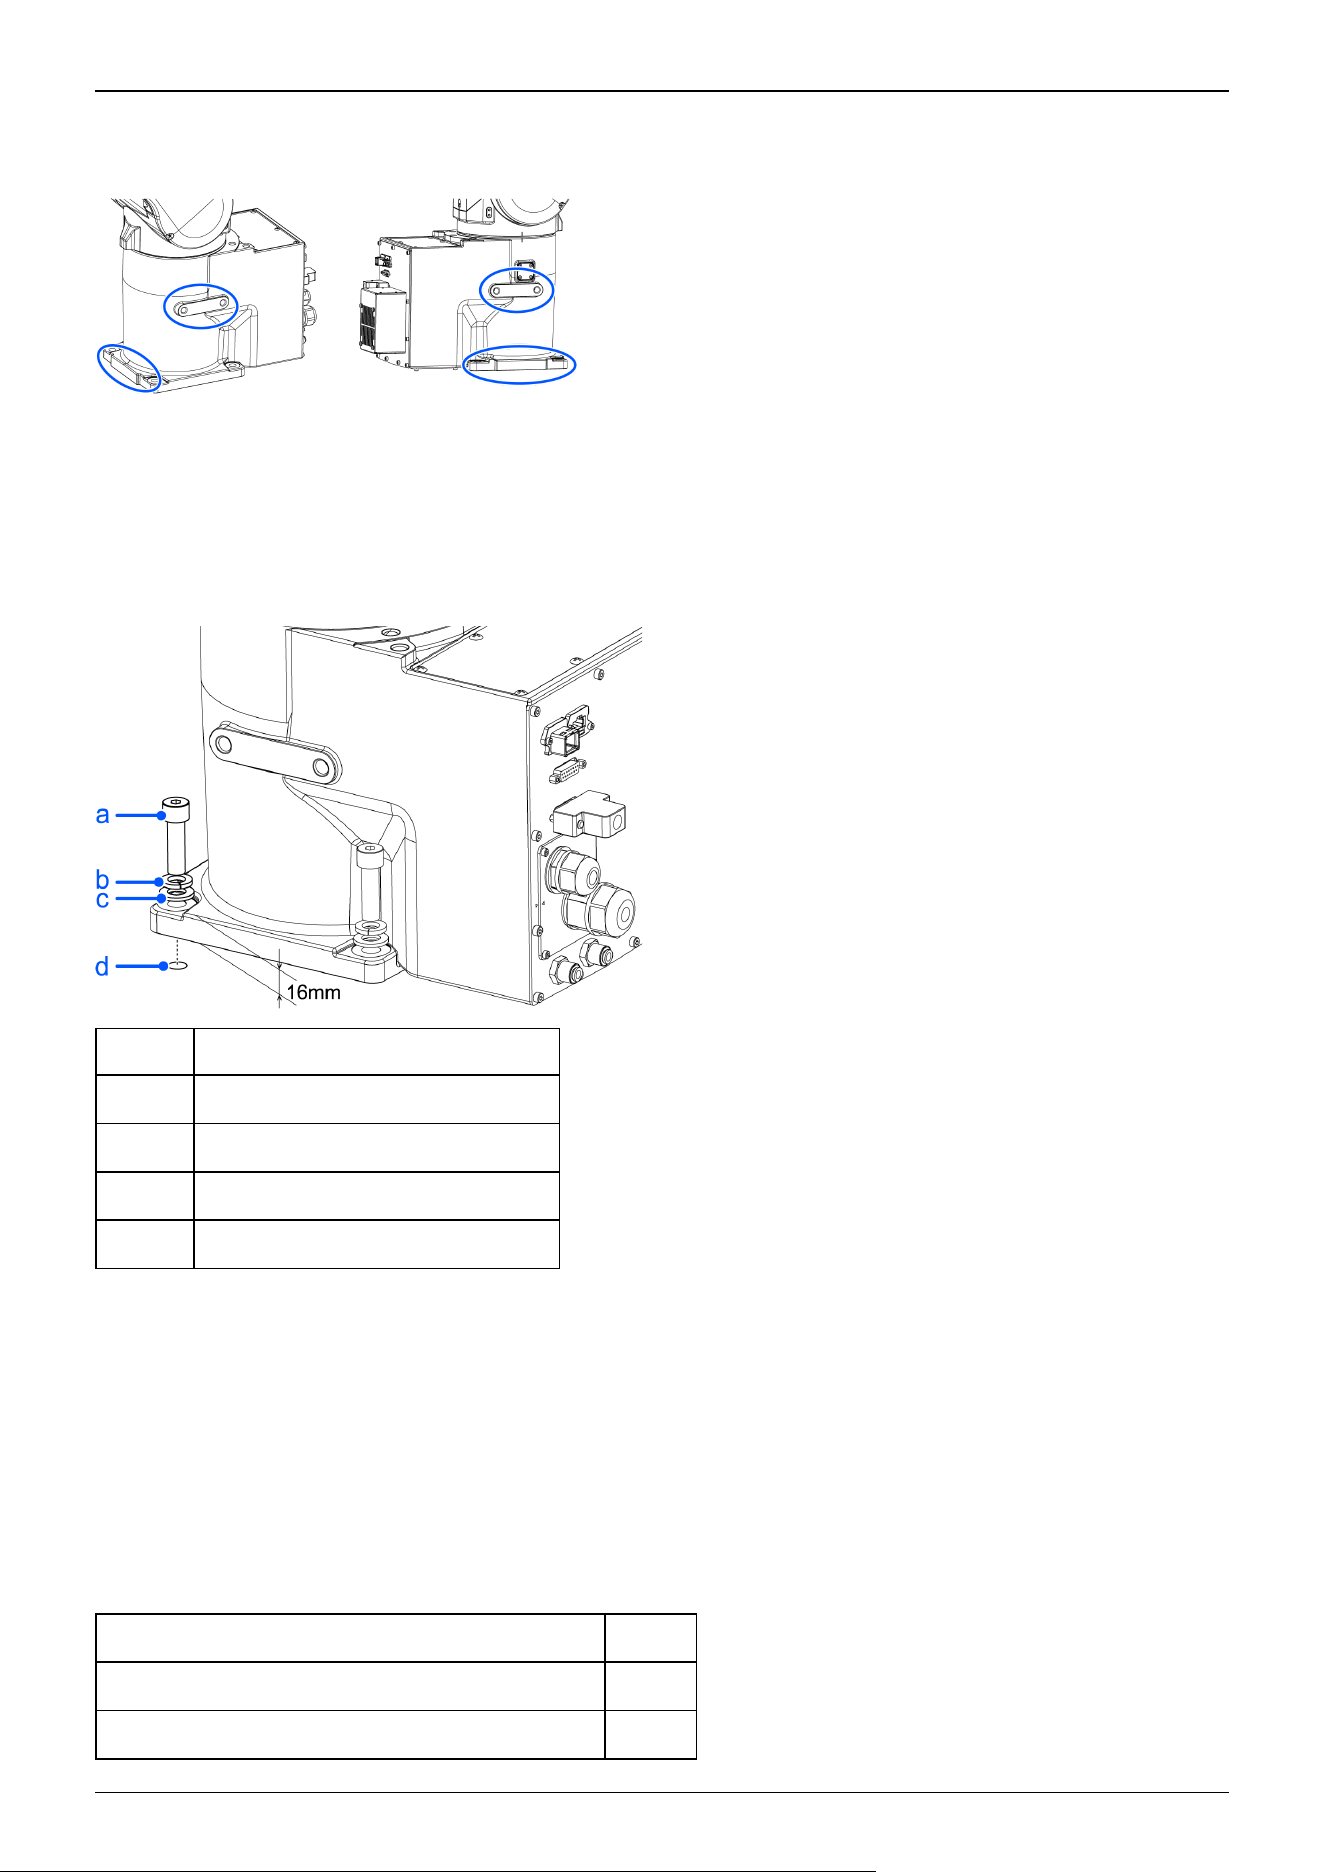
Protective tape
Remove the protective tape (4 places).
Fixing bolt
For details on the dimensions, refer to the following sections.
Manipulator Mounting Dimensions
There are four threaded holes for the Manipulator base. Use M12 mounting bolts conforming to the strength equivalent to
ISO898-1 property class 10.9 or 12.9. Tightening torque: 100.0 ± 5.0 N·m (1,020 ± 51 kgf·cm)
Symbol Description
a 4×M12×40
b Spring washer
c Plain washer
d Threaded hole (25 mm or more depth)
Base table
A base table for anchoring the Manipulator is not supplied. The base table must be fabricated or obtained by the customer.
The shape and size of the base table vary depending on the application of the robot system. As a reference when designing the
base table, the requirements from the Manipulator side are shown here.
The base table must not only be able to bear the weight of the Manipulator but also be able to withstand the dynamic
movement of the Manipulator when it operates at maximum acceleration/deceleration. Ensure that there is enough strength on
the base table by attaching reinforcing materials such as crossbeams.
Followings are the torque and reaction force produced by the movement of the Manipulator.
Maximum rotating torque on horizontal surface (N·m) 2600
Maximum reaction force in horizontal direction (N) 1000
Maximum rotating torque on vertical surface (N·m) 3400
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
101
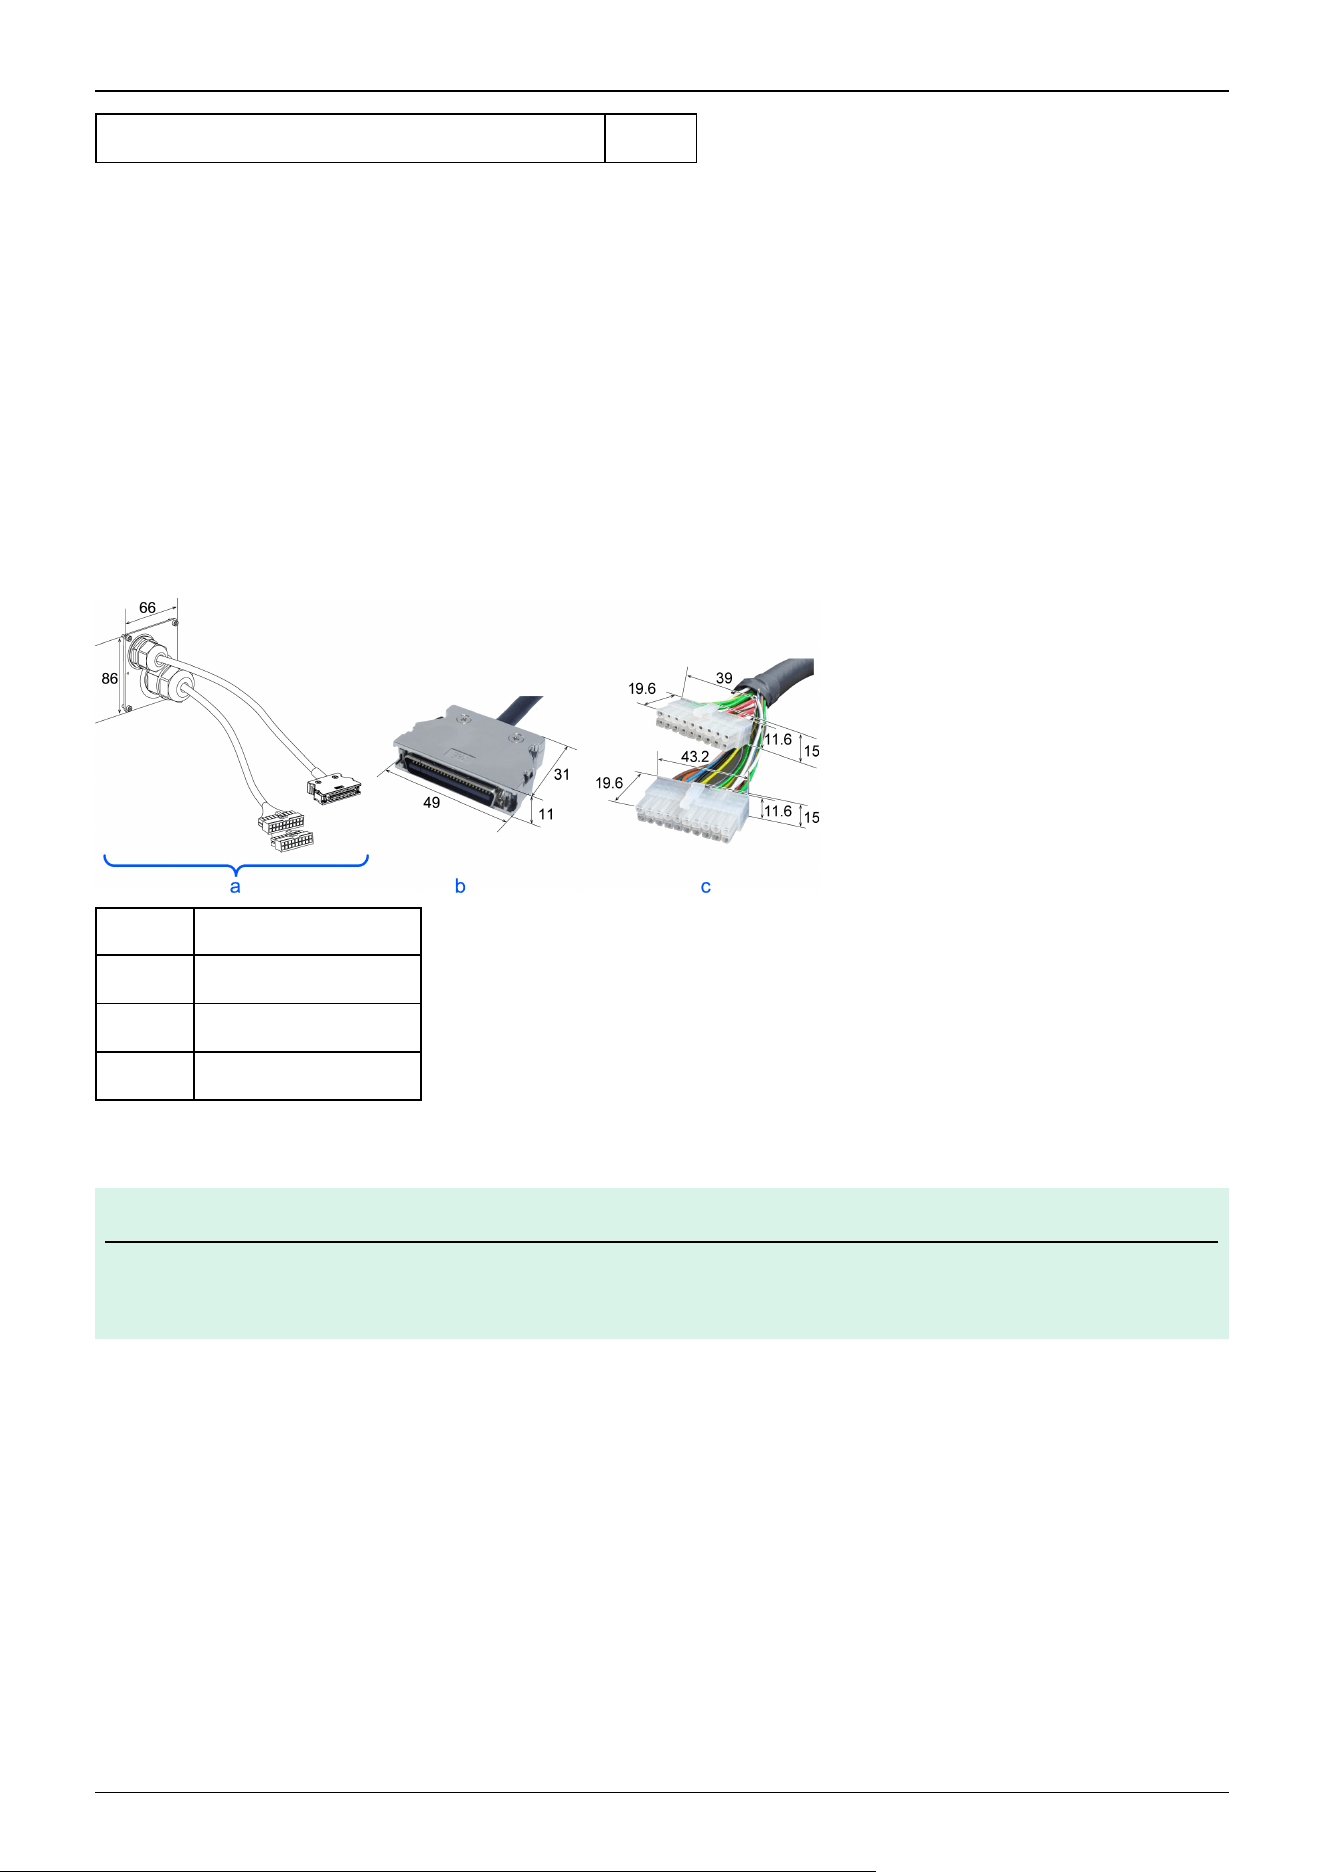
Maximum reaction force in vertical direction (N) 7900
The plate for the Manipulator mounting face should be at least 30 mm thick and made of steel for reducing vibrations.
A surface roughness of 25 μm or less at the maximum height is appropriate.
The base table must be secured on the floor to prevent it from moving.
The Manipulator installation surface should have a flatness of 0.5 mm or less and an inclination of 0.5° or less. If the
installation surface does not have the proper flatness, the base of the Manipulator may be damaged or the robot may be unable
to operate at maximum performance.
When using a leveler to adjust the height of the base table, use a screw with M16 diameter or more.
Connector
If passing cables through the holes in the base table, refer to the connector dimensions in the figures below. (Units: mm)
Symbol Description
a M/C cable
b Signal cable connector
c Power cable connector
Do not remove the M/C cables from the Manipulator.
KEY POINTS
For details on the environmental requirements for the space when housing the Controller in the base table, refer
to the Robot Controller manual.
When using the Manipulator in the clean room, follow the steps below before the installation.
1. Unpack the Manipulator outside of the cleanroom.
2. Secure the Manipulator to transporting equipment (or a pallet) with bolts so that the Manipulator does not fall down.
3. Wipe off any dust on the Manipulator using a lint-free cloth that was dipped in ethyl alcohol or distilled water.
4. Carry the Manipulator into the cleanroom.
5. Secure the Manipulator to the base table.
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
102
3.3.4 Connecting the Cables
WARNING
Before performing any replacement work, turn off the Controller and related equipment, and unplug the power
cable from the power source. Performing any work procedure with the power turned on is extremely
dangerous and may result in electric shock and/or malfunction of the robot system.
Be sure to connect the AC power cable to a power outlet. Do not connect it directly to a factory power source.
To perform the power supply lockout, remove the power plug. Working while connecting the AC power cable
to a factory power source may result in electric shock and/or malfunction of the robot system.
Be sure to connect the cables properly. Do not put heavy objects on the cables, bend or pull on the cables
forcibly, or allow the cables to be pinched. Damaged cables, broken wires, or contact failure is extremely
hazardous and may result in electric shock and/or malfunction of the robot system.
Be sure to turn off the power and tag out (e.g., with a "DO NOT TURN ON" sign) before performing wiring.
Performing any work procedure with the power turned on is extremely dangerous and may result in electric
shock and/or malfunction of the robot system.
The Manipulator is grounded by connecting it to the Controller. Ensure that the Controller is grounded and the
cables are correctly connected. If the ground wire is improperly connected to ground, it may result in the fire
or electric shock.
Turn off the power to the Robot Controller and brake release unit when connecting or replacing the brake
release unit or external short connector. Inserting or removing connectors with the power on may result in
electric shock and/or malfunction of the robot system.
CAUTION
When connecting the Manipulator and the Controller, check that the serial numbers match for each device.
Improper connection between the Manipulator and the Controller may not only lead to malfunction of the robot
system but also safety problems. The connection method between the Manipulator and the Controller varies
depending on the Controller. For details on the connection, refer to the following manual.
"Robot Controller Manual"
Only authorized or certified personnel should perform wiring. Wiring by unauthorized or uncertified staff may
result in bodily injury and/or malfunction of the robot system.
Operating the Manipulator without a brake release unit or external short connector connected may cause the
brake to fail to release, possibly damaging the brake.
After using the brake release unit, be sure to connect the external short circuit connector to the Manipulator or
make sure to leave the connector for the brake release unit connected.
Cleanroom-model Manipulator
When the Manipulator is a model with cleanroom specifications, an exhaust system must be connected. For the exhaust
system, refer to the following section.
C12 Specifications
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
103
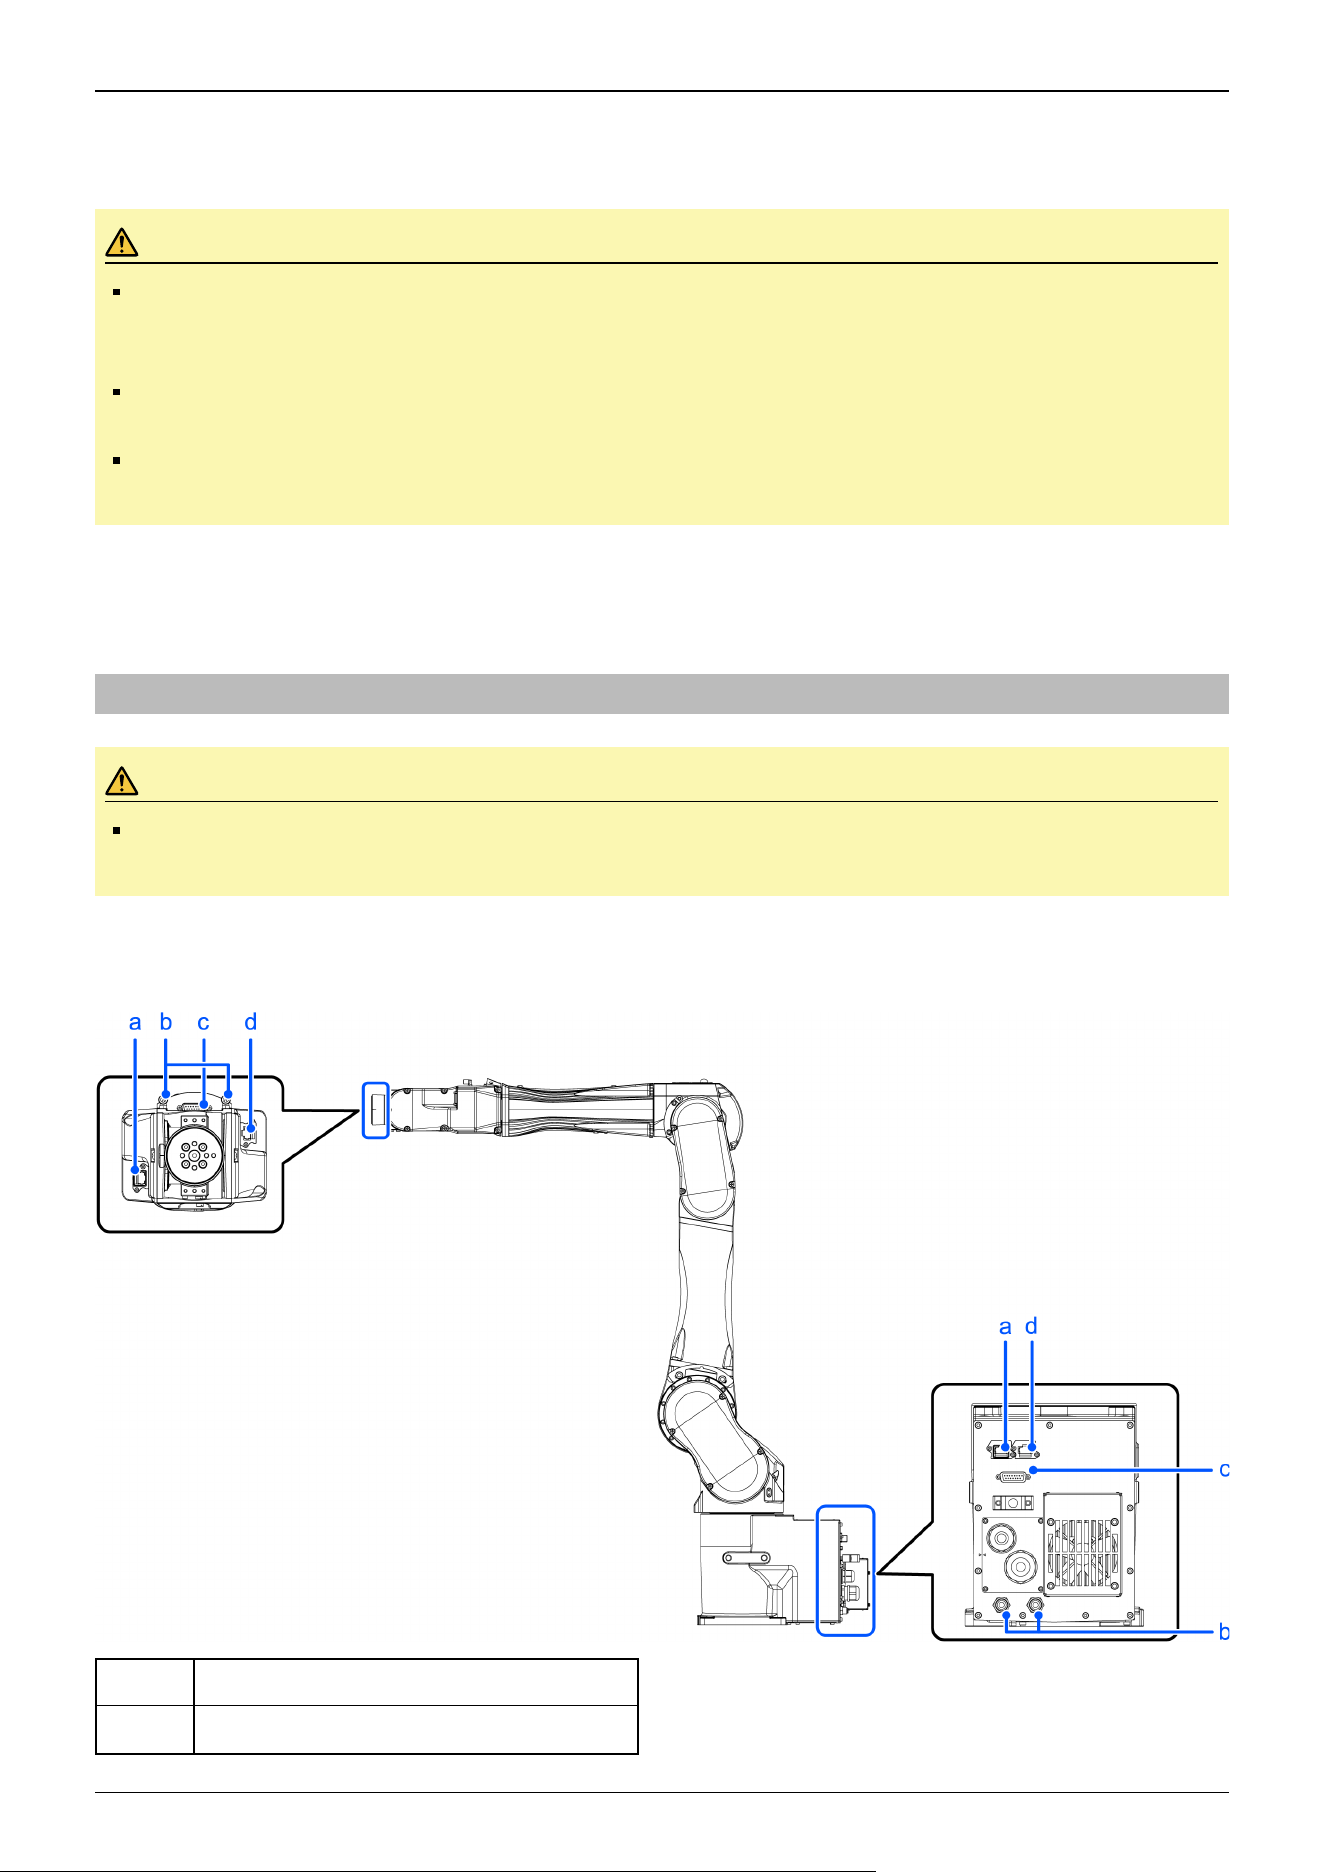
Protected-model Manipulator
When the Manipulator is a protected-model, please note the following points.
CAUTION
When operating Manipulators in special environments (oil smoke, dust, etc.), do not install the Controller in
the same environment. The Controller does not satisfy the protection class (IP67). Using the Controller in
these special environments may damage or lead to a breakdown of the Controller.
After using the brake release unit, be sure to reconnect the external short connector to the Manipulator. The
break release unit does not satisfy the protection class (IP67).
Be sure to connect a connector compliant with protection class IP67 or higher and a connector cover to the
Ethernet cable connector.
Connection procedure for M/C cable
Connect the power connector and signal connector of the M/C cable to the Controller.
3.3.5 User Wires and Pneumatic Tubes
CAUTION
Only authorized or certified personnel should perform wiring. Wiring by unauthorized or uncertified staff may
result in bodily injury and/or malfunction of the robot system.
User electrical wires and pneumatic tubes are contained in the cable unit.
Cable backward model
Symbol Description
a Force Sensor cable connector
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
104
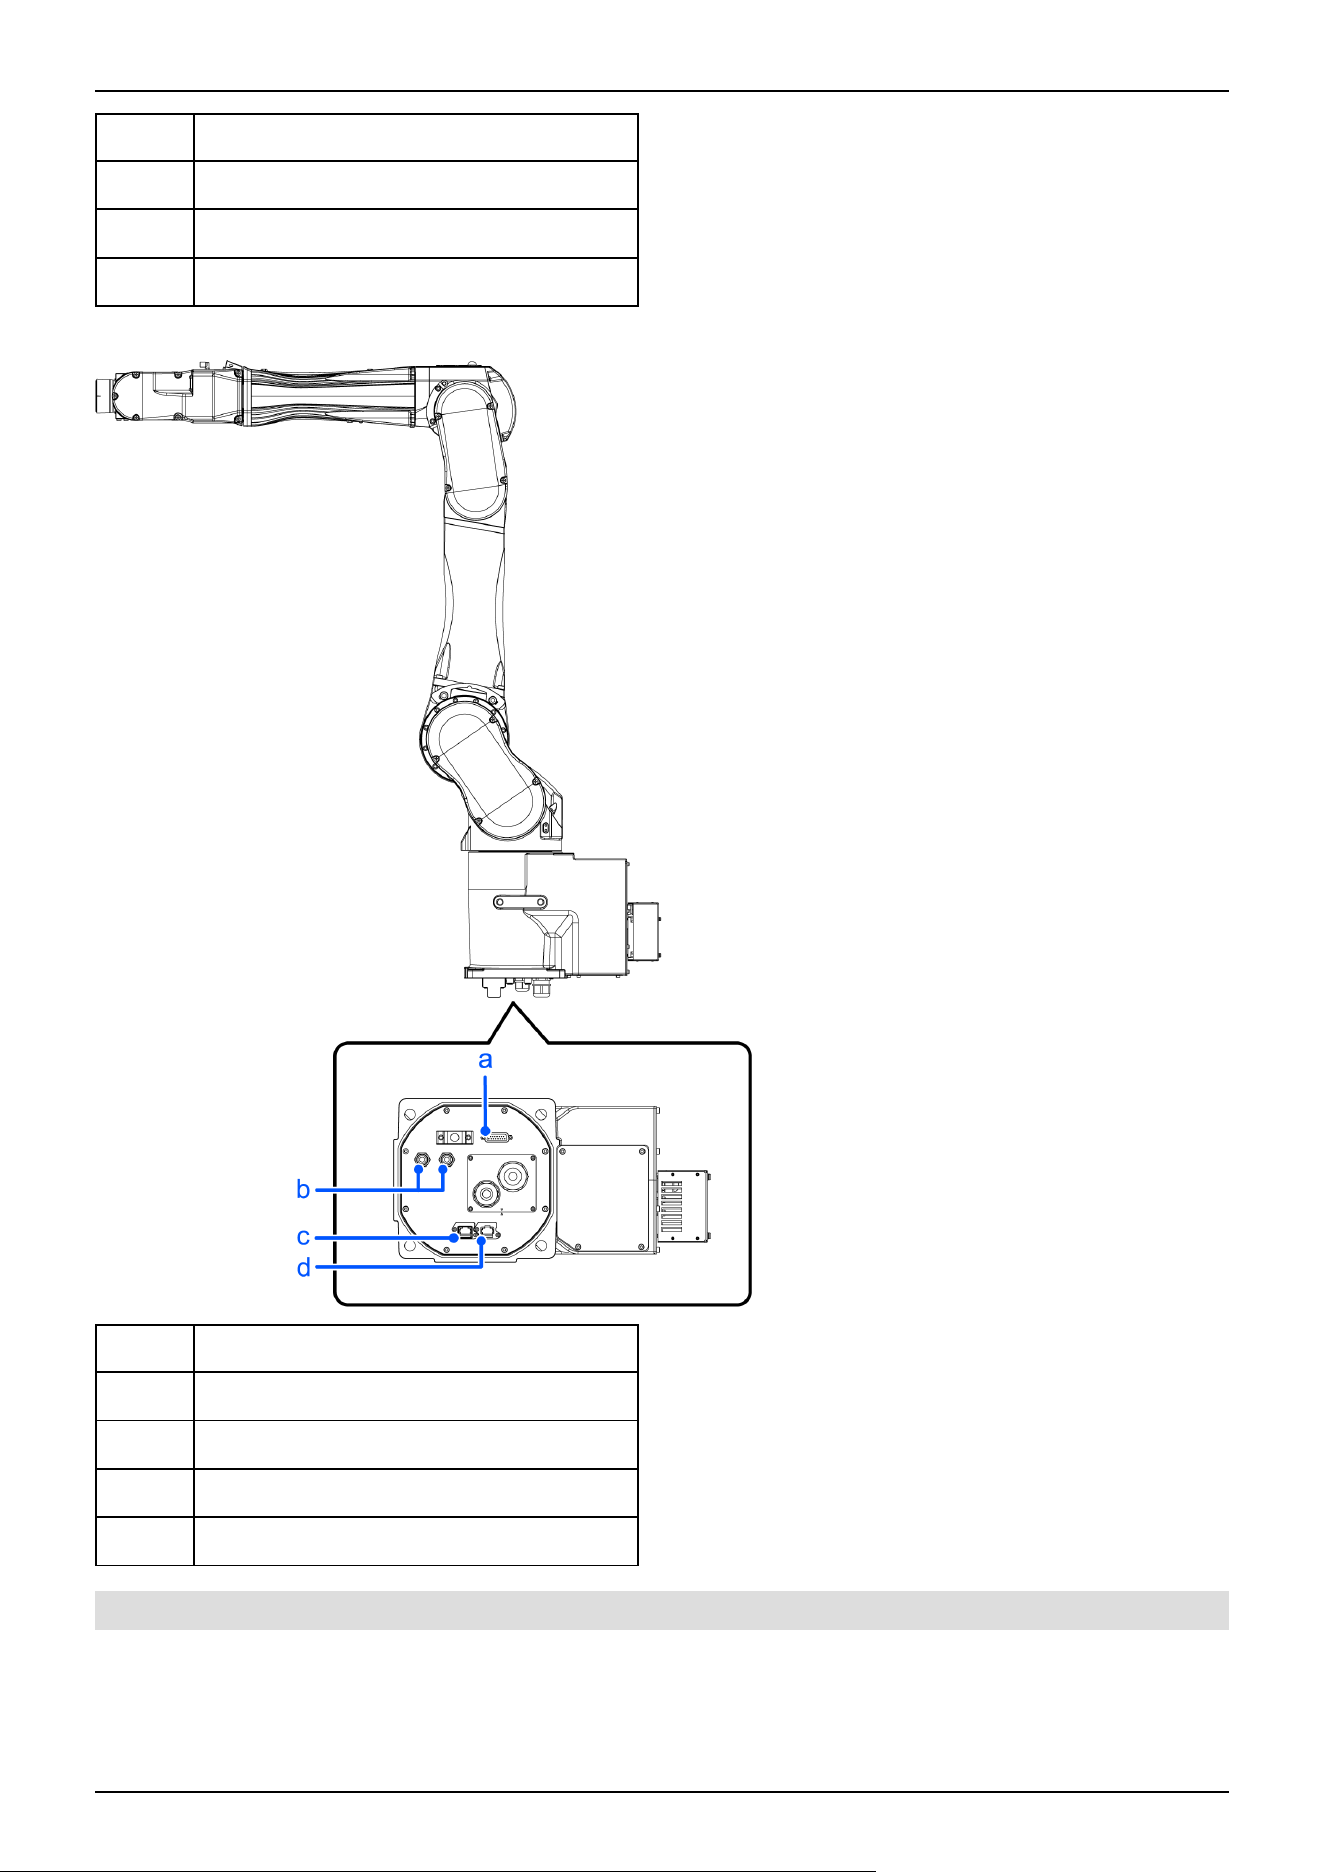
Symbol Description
b Fitting for ⌀6 mm tube (Air1, Air2)
c User cable connector (15-pin D-sub connector)
d Ethernet cable connector
Cable downward model
Symbol Description
a User cable connector (15-pin D-sub connector)
b Fitting for ⌀6 mm tube (Air1, Air2)
c Force Sensor cable connector
d Ethernet cable connector
3.3.5.1 Electrical Wires
Specifications of the user wires D-sub 15-pin
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
105
Rated Voltage Allowable Current Wires Nominal Sectional Area Note
AC/DC30V 1 A 15
0.106 mm
2
Shielded
Pins with the same number, indicated on the connectors on both ends of the cables, are connected.
Attached connector for user wires (standard, cleanroom model)
Manufacturer Type
15 pin
Connector JAE DA-15PF-N (Solder type)
Clamp hood HRS HDA-CTH (4-40) (10) (Connector setscrew: #4-40 UNC)
Two parts are attached for each.
Attached connector for user wires (protected-model)
Manufacturer Type
15 pin
Connector HARTING 09 67 015 5615 (Solder type)
Clamp hood HARTING 09 67 015 0538 (Connector setscrew: #4-40 UNC)
Two parts are attached for each.
8-pin (RJ45) equivalent to Cat.5e
An Ethernet cable (commercially available) can be connected to Manipulator models with standard and cleanroom
specifications.
For the protected-model, use the following optional part.
User connector kit (IP67 waterproof, for RJ45, 2 pcs)
For details, refer to the following section.
Other
The 6-pin cable for the Force Sensor option is included.
3.3.5.2 Pneumatic Tubes
Maximum Working Pressure Number of Tubes Outer Diameter × Inner Diameter
0.59 MPa (6 kgf/cm
2
: 86 psi)
2 ⌀6 mm × ⌀4 mm
The elbow fitting is attached on the Arm #4 at the time of shipment. The part can be replaced with the straight fitting
(accessory) according to application.
Protected-model:
The plugs are installed on the Arm #4 and the base. To use the pneumatic tubes, remove the plugs and install the fittings
(accessory) on the Arm #4.
Threaded hole size for installing the Arm #4 fitting: M6
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
106
When the Manipulator is a protected-model, please note the following points.
CAUTION
In special environments (e.g., oil smoke, dust, etc.), the user wires and pneumatic tubes should have
protected-model (compliant with protection class IP67). If the user wires and pneumatic tubes not protected-
model are connected, the protection class (IP67) cannot be guaranteed, and the Manipulator may be
damaged or break down.
Be sure to attach the cap or plug (attached at the time of shipment) on the user cable connector when not
using the user cable connector or the pneumatic tubes. Using the Manipulator without the cap or plug may
cause equipment damage to and/or malfunction of the Manipulator as dust or oily smoke gets into the
connector.
3.3.6 Checking the Basic Orientation
After installing the Manipulator and setup the operating environment, check if it moves to the basic position properly.
Follow the steps below to set the basic orientation of the Manipulator shown below as the origin position.
1. Start Epson RC+.
Double click the [Epson RC+] icon on the desktop.
2. Open the command window.
Epson RC+ menu-[Tools]-[Command Window]
3. Execute the following command in [Command Window].
>Motor On
>Go Pulse (0,0,0,0,0,0)
KEY POINTS
If "Error 4505: cannot be turned on the motor because the Safety Board is issuing a stop signal." occurs, use one
of the following methods to move the Manipulator to its basic orientation.
Release the brake and push the arm by hand to move it within the motion range. Then follow the steps above.
For details on releasing brake, refer to the following section.
How to Move Arms with the Electromagnetic Brake
Press the TP3 or TP4 command button [Pulse0] to move the Manipulator to its basic orientation. For details,
refer to the following manuals.
For TP3:
"Robot Controller Option Teach Pendant TP3 Operation 3.1.3 Command Buttons"
For TP4:
"Robot Controller Option Teach Pendant TP4 3.2.5.13.2 Command Buttons"
"Robot Controller Option Teach Pendant TP4 3.2.9.7.2 Command Buttons"
If the Manipulator cannot be in the basic orientation shown below, please contact the supplier.
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
107
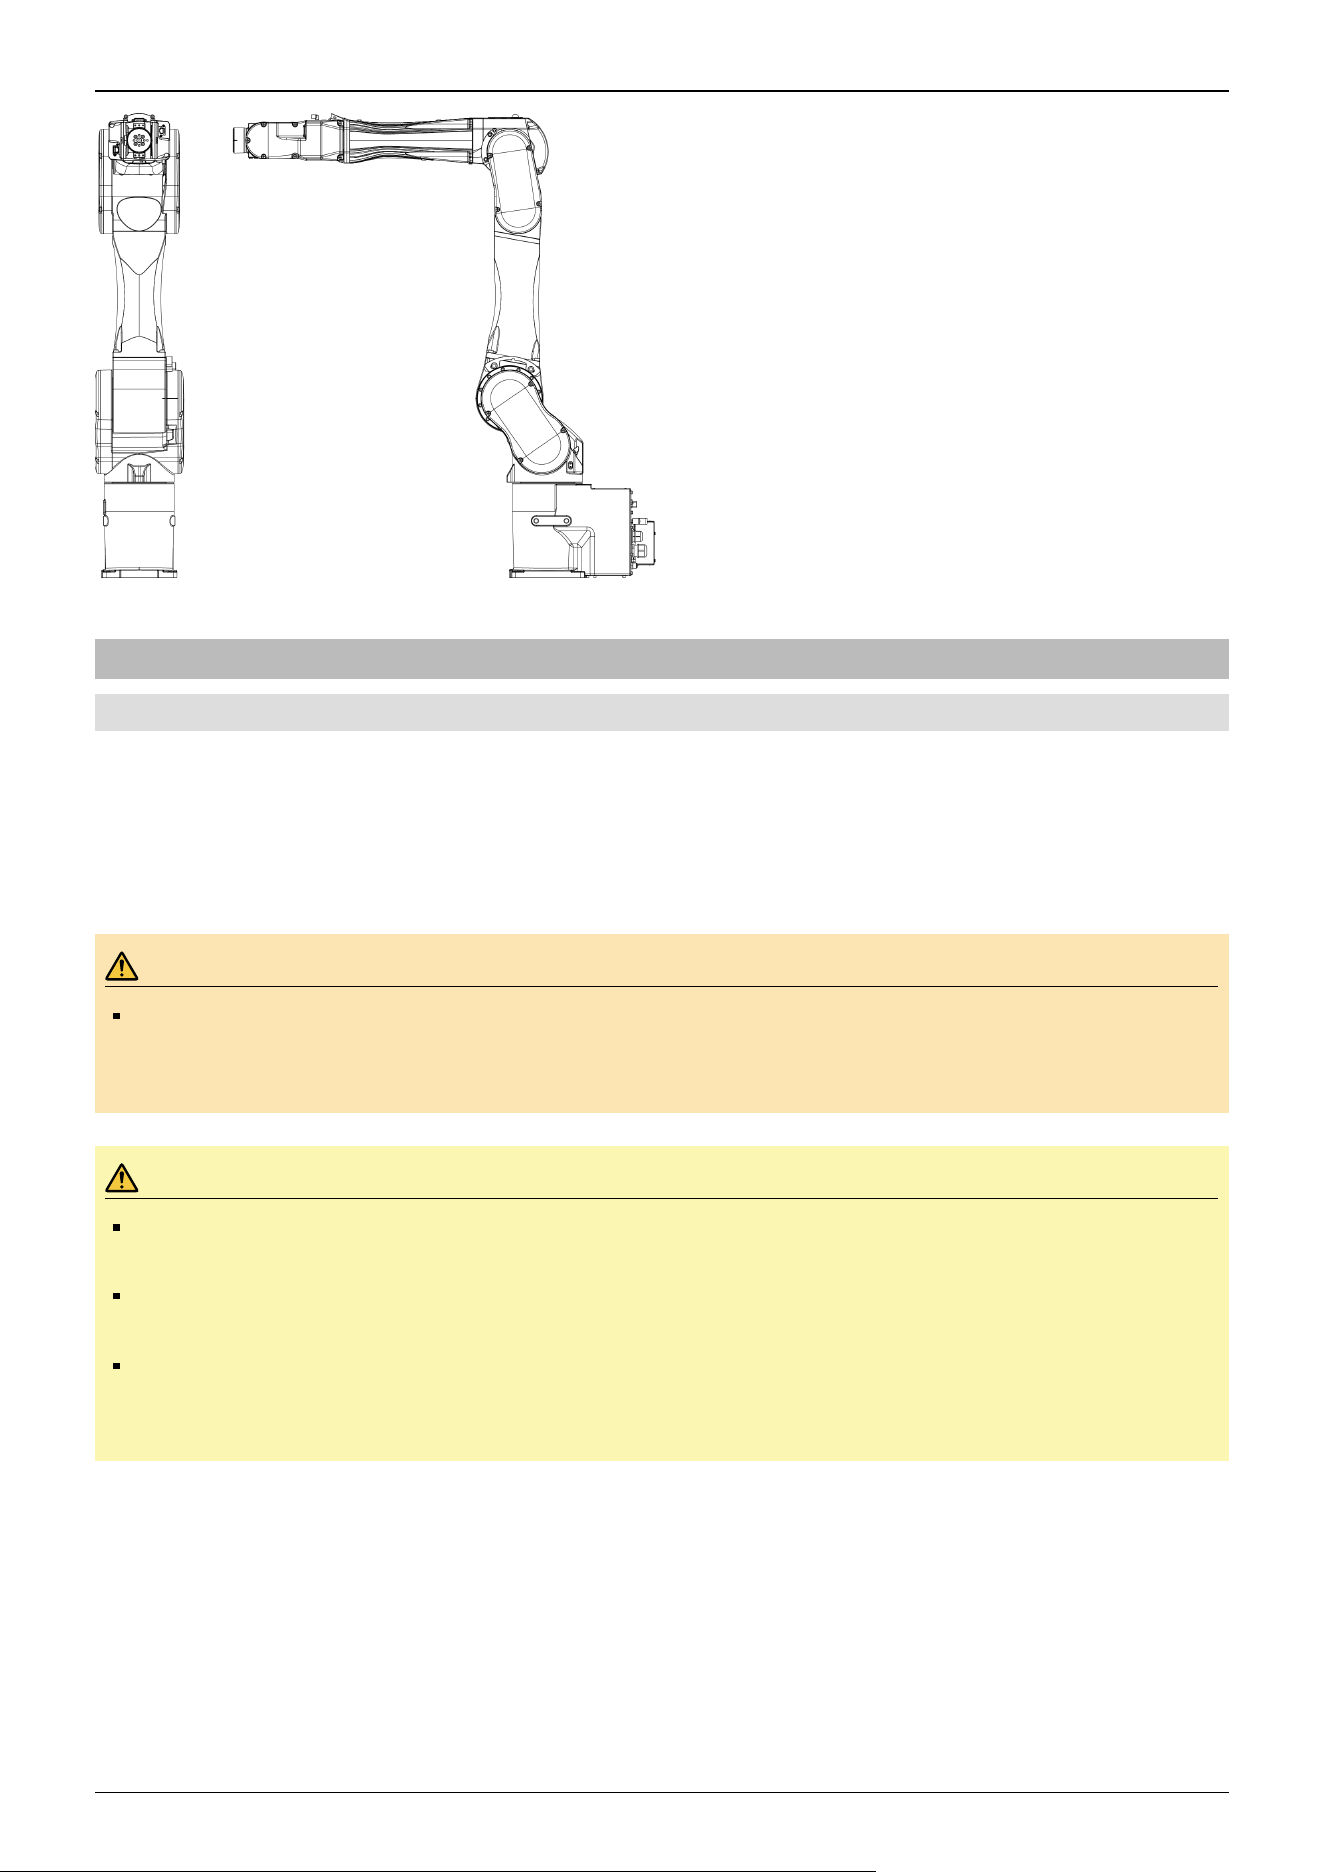
3.3.7 Relocation and Storage
3.3.7.1 Safety Information for Relocation and Storage
Pay attention to the following requirements when relocating, storing, and transporting the Manipulators.
Transportation and installation of the Manipulator and related equipment should be performed by people who have received
installation training provided by Epson and the suppliers. Also, the laws and regulations of the installation country must be
followed.
WARNING
Only qualified personnel should perform sling work and operate a crane or a forklift. When these operations
are performed by unqualified personnel, it is extremely hazardous and may result in serious bodily injury
and/or severe equipment damage to the robot system
CAUTION
Before relocating, fold the arm and secure it tightly with a cable tie to prevent hands or fingers from getting
caught in the Manipulator.
When removing the anchor bolts, support the Manipulator so that it does not fall. Removing the anchor bolts
without supporting the Manipulator can cause it to fall, causing hands or feet to get caught.
The Manipulator should be transported by two or more people or secured to transporting equipment. Also, do
not hold the bottom of the base. Holding these parts by hand is extremely hazardous and may cause your
hands and fingers caught.
During unpacking and relocation, avoid applying external force to the arms and motors of the Manipulator.
When transporting the Manipulator over long distances, secure it directly to transporting equipment so that it will not fall. If
necessary, pack the Manipulator using the same packaging as delivery.
When the Manipulator is reassembled and used for a robot system again after an extended period of storage, perform a test run
to verify that it works properly before starting the main operation.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
108
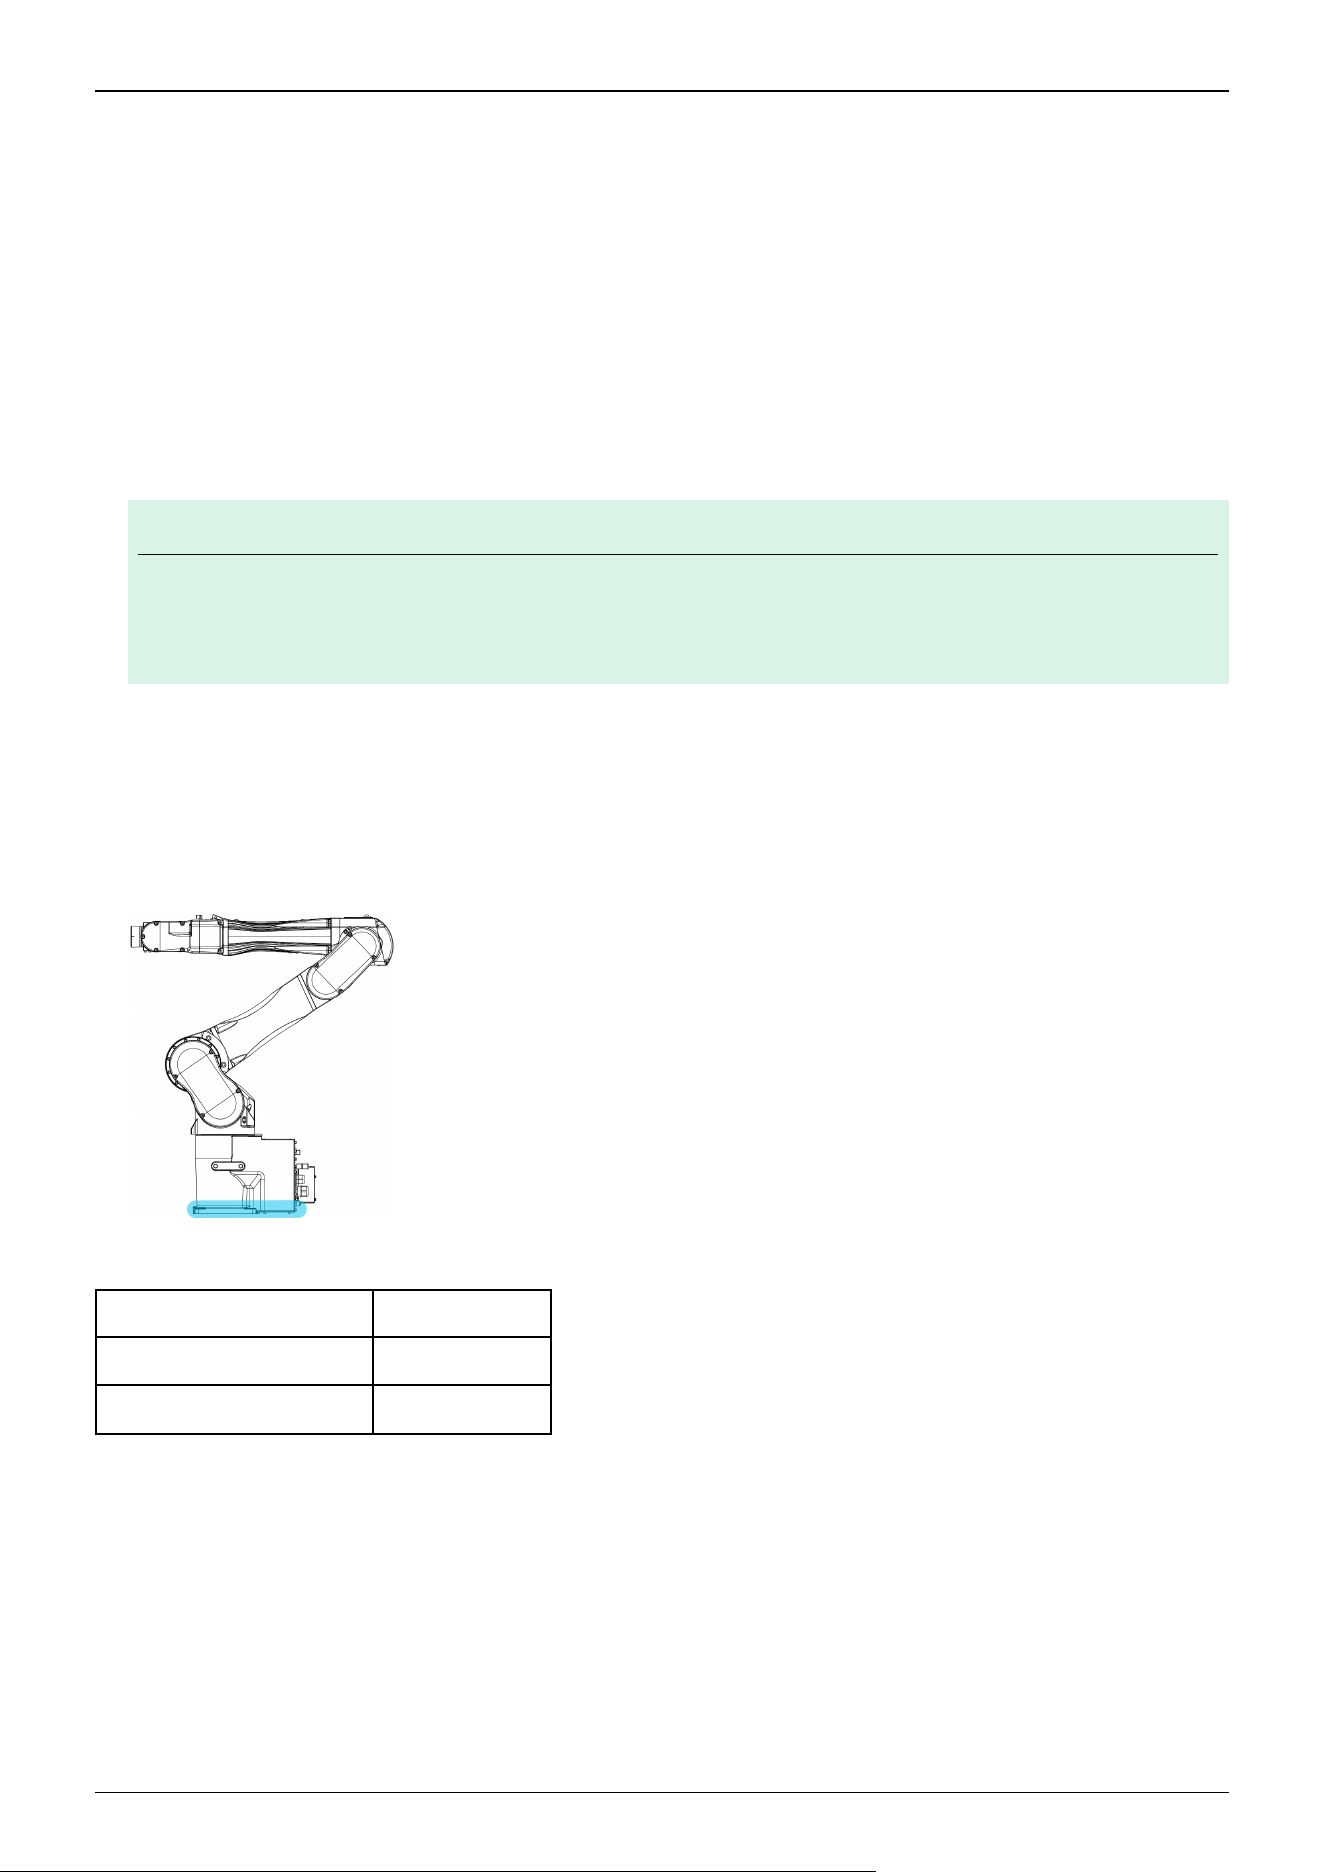
Manipulators should be transported and stored under the following conditions: Temperature: -20 to +60°C, Humidity: 10 to
90% (no condensation)
If condensation has formed on the Manipulator during transportation or storage, do not turn on the power until the
condensation is removed.
Do not subject the Manipulator to excessive impacts or vibrations during the transportation process.
Relocation
Follow the procedures described below when relocating the Manipulator.
1. Turn off the power for all devices and unplug the power cable connector and signal cable connector from the Controller.
Do not remove the M/C cables (power cable and signal cable) from the Manipulator.
KEY POINTS
Remove the mechanical stops if using them to limit the motion range. For details on the motion range, refer to
the following section.
Setting the Work Envelope by Mechanical Stops
2. Unscrew the anchor bolts. Then, remove the Manipulator from the base table.
3. Position the Manipulator as shown in the figure. Then, secure the Manipulator to the transporting equipment or have at
least two people to relocate the Manipulator. (Recommend: Joint #2 +55°. Joint #3 -55°)
The posture is common to all models.
Do not hold the bottom of the base (the screened parts in the figure). Holding these parts by hand is extremely hazardous
and may cause your hands and fingers caught.
Manipulator weight
C12-C1401S***
Standard, Cleanroom Model 63 kg: 139 lb
Protected-Model 67 kg: 148 lb
Using eyebolts
Check that the eyebolts are securely fastened before transporting the Manipulator. After transporting the Manipulator, remove
the eyebolts and keep them for future use.
The eyebolts (accessory, 2 pcs) and wire must be strong enough to withstand the weight (See the figures below).
If you use the eyebolts to lift up the Manipulator, make sure to put hands on it to keep the balance. The Manipulator may fall if
the balance is lost and this is extremely hazardous.
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
109
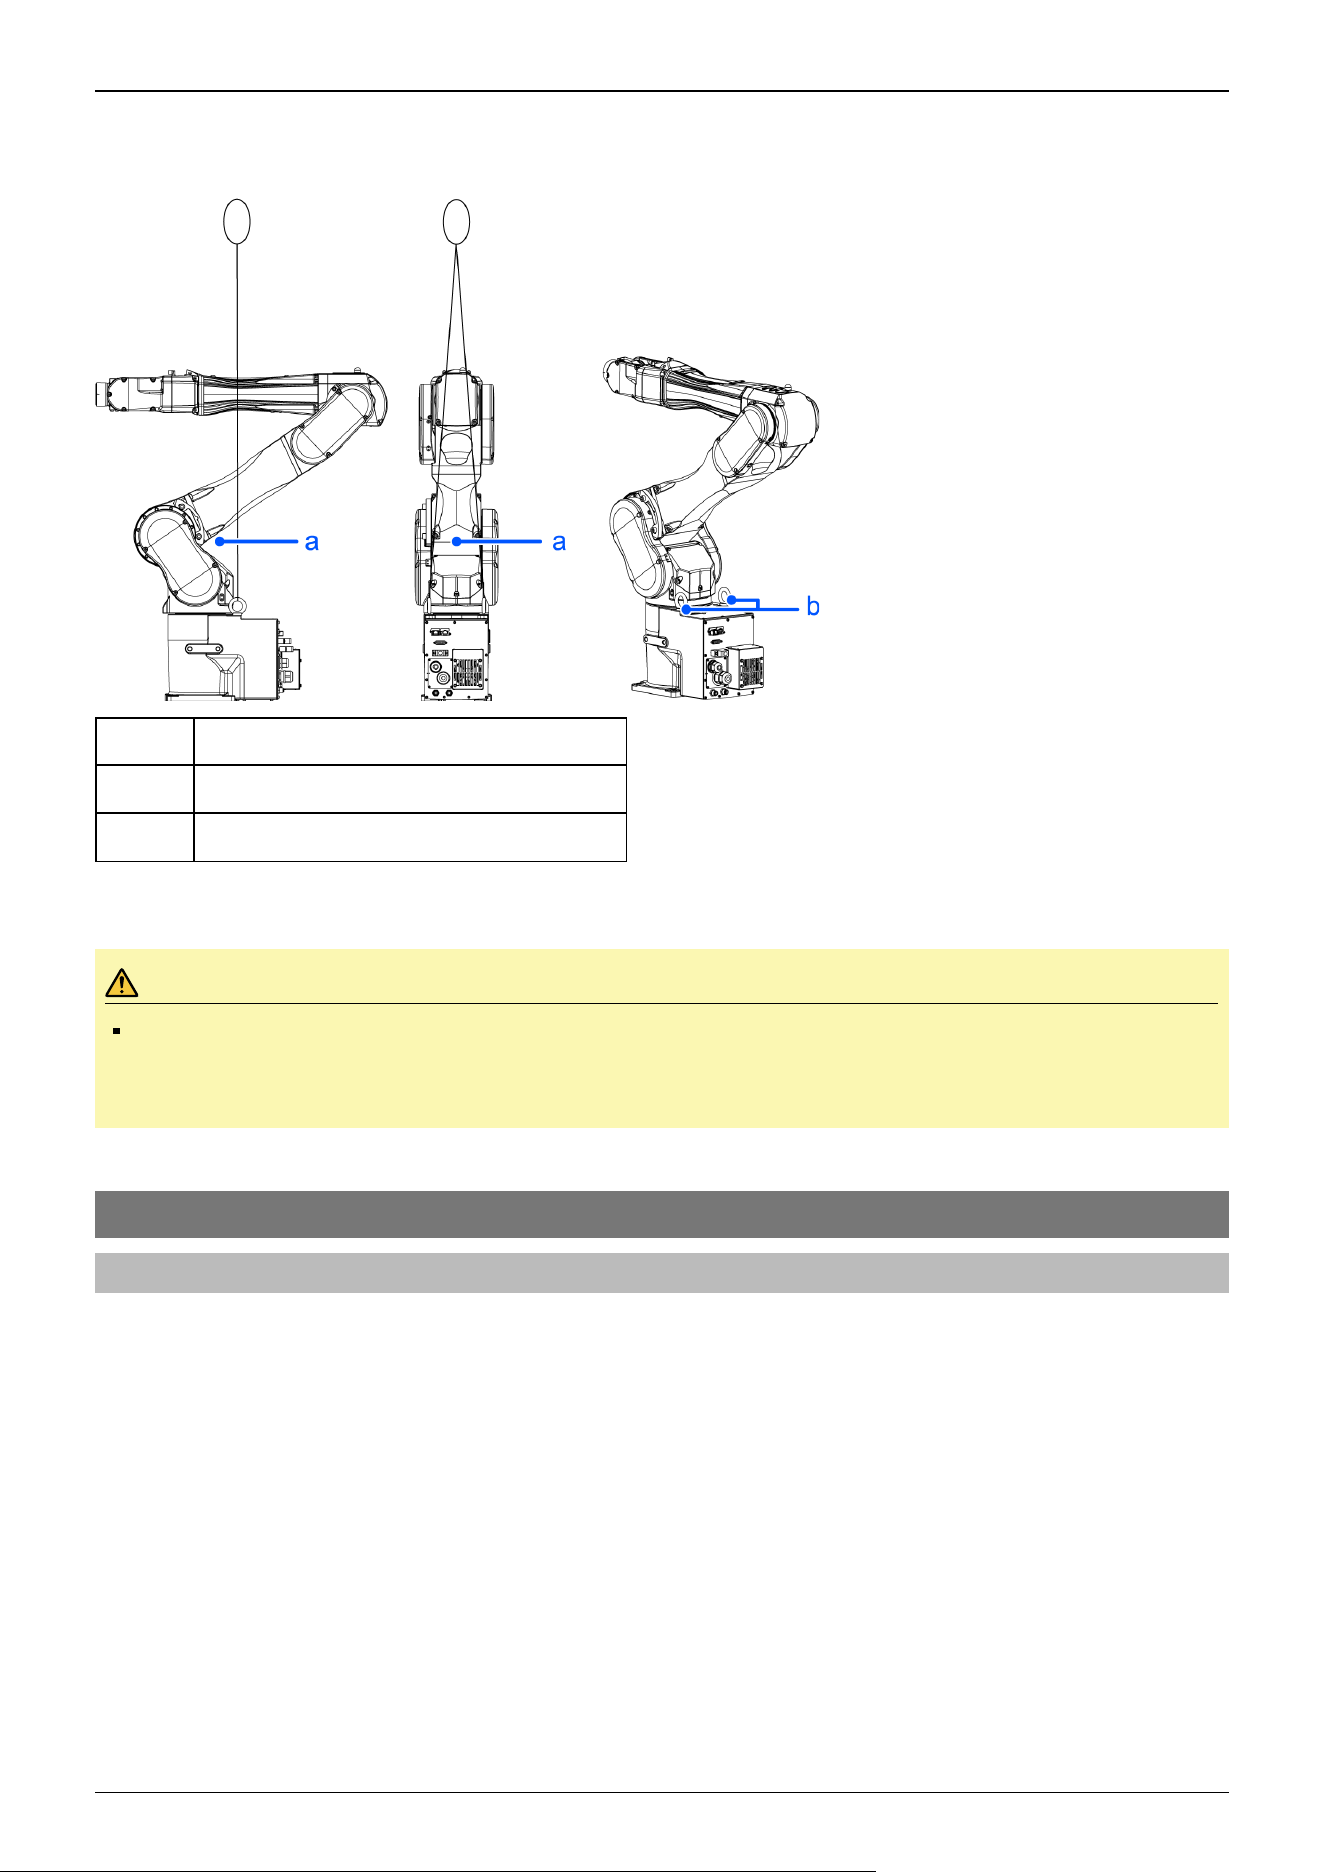
To prevent damage on the covers and arms, it is recommended to protect the contacting parts of the wire and arm with a cloth.
Be very careful not to damage the covers since they are made of plastic.
Symbol Description
a Center of gravity
b Threaded holes for eyebolts: 2×M12 depth 25
Locations of the threaded holes for eyebolts are common to all models.
CAUTION
Remove the eyebolts from the Manipulator after transportation/relocation is completed. If the Manipulator is
operated with the eyebolts left on it, the arm may collide with the eyebolts and it may cause equipment
damage to and/or malfunction of the Manipulator.
3.4 Setting the Hand
3.4.1 Installing the Hand
The hand (end effector) must be prepared by the customer. For details on attaching the hand, refer to the following manual.
"Hand Function Manual"
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
110
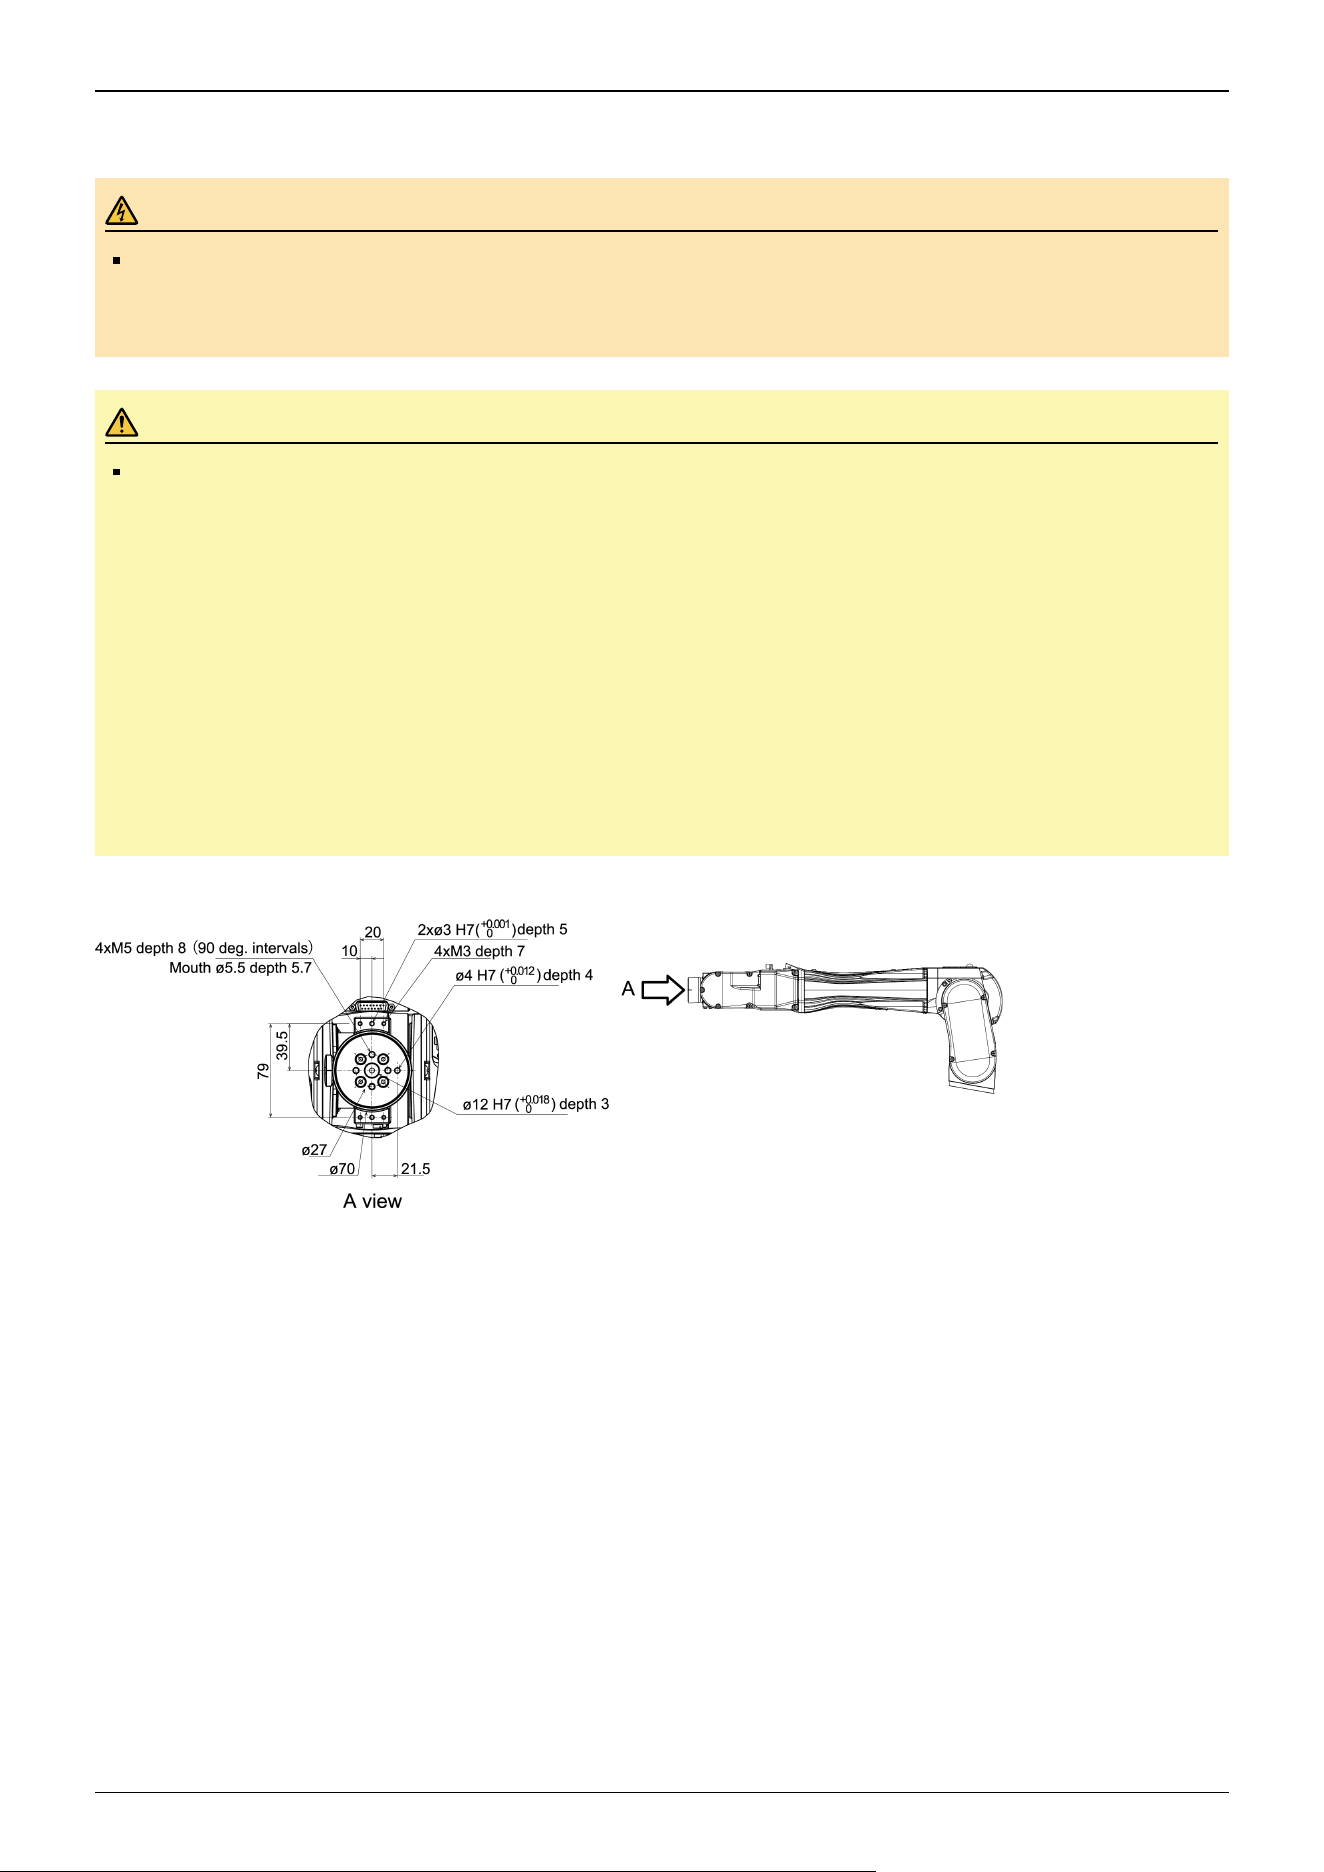
Flange dimensions of the wrist attached to the end of Arm #6 is as below.
WARNING
Before attaching a hand or peripheral equipment, be sure to always turn off the Controller and related
equipment and unplug the power cables. Performing any work procedure with the power turned on is
extremely dangerous and may result in electric shock and/or malfunction of the robot system.
CAUTION
When the hand is equipped with a workpiece gripping mechanism, ensure that the wiring and pneumatic
tubes do not cause the hand to release the workpiece when the power is turned off. When the wiring and
pneumatic tubes are not designed for the hand to maintain its grip on the workpiece when the power is turned
off, pressing the emergency stop switch releases the workpiece, which may damage the robot system and the
workpiece.
By default, all I/Os are designed to automatically turn off (0) when the power is shut off, when an emergency
stop is triggered, or by the robot system's safety function.
However, I/Os set with the Hand function does not turn off (0) when executing the Reset statement, or when
performing an emergency stop.
For the risk of the residual air pressure, conduct a risk assessment on the equipment and take the necessary
protective measures.
Wrist flange
Arm #6
Attach the hand to the end of the Arm #6 using the M5 bolts.
Layout
When attaching and operating a hand, the hand may come into contact with the Manipulator body due to the outer diameter of
the hand, the size of the workpiece, or the position of the arm. Carefully consider the interference area of the hand when
designing the system layout.
Compatibility with ISO flange
To install the hand whose mounting dimensions are designed for the ISO flange, we provide the optional C8 ISO flange (J6).
For details, refer to the following section.
Options
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
111
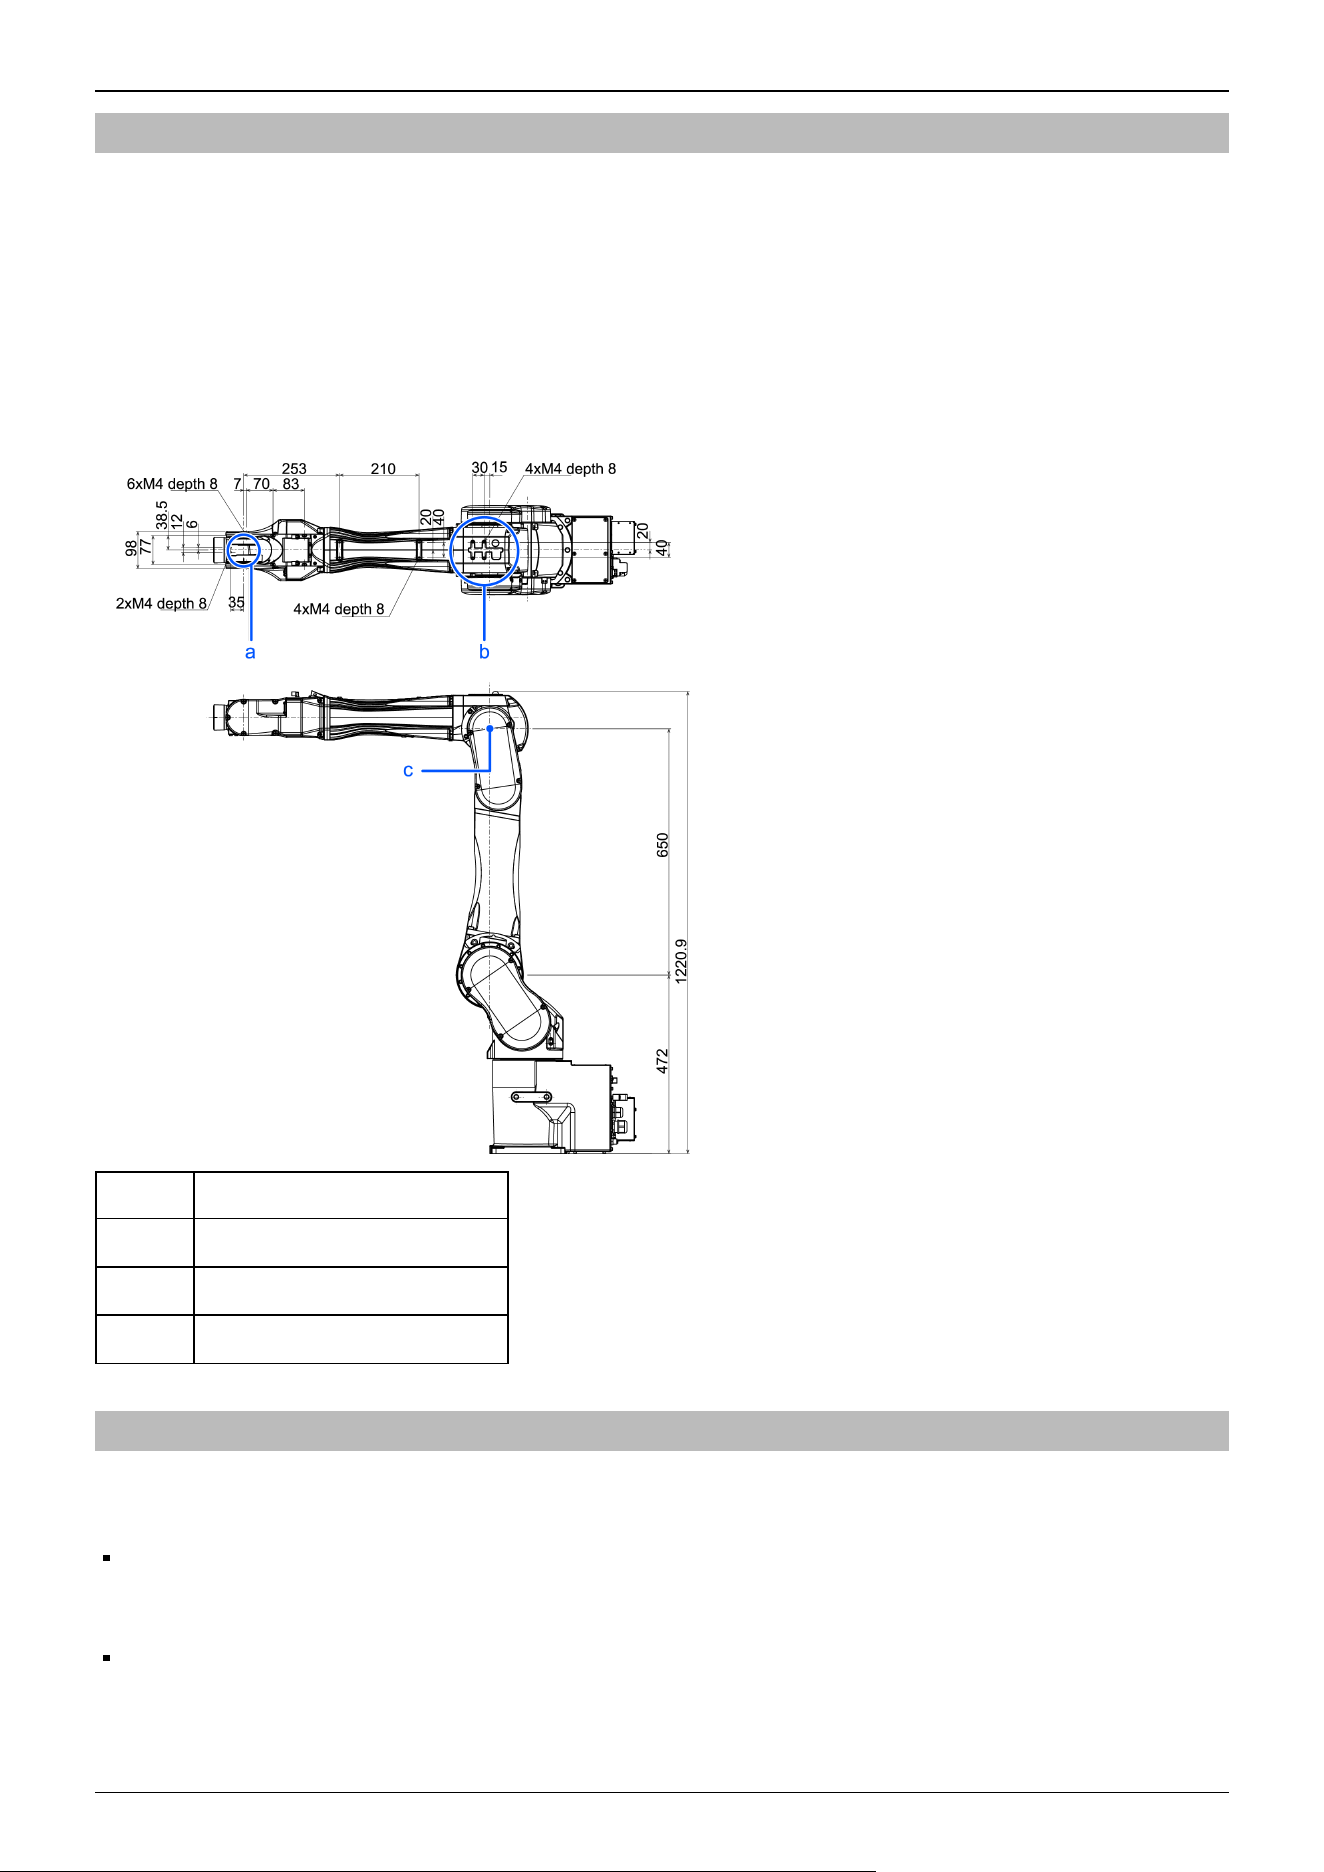
3.4.2 Attaching Cameras and Valves
Decks are equipped to Arms #3 and #5 to enable the easy installation of air valve. If the payload exceeds the maximum
payload, refer to the following section.
"WEIGHT Setting - Restrictions on payload exceeding the maximum payload"
To mount the camera, the camera plate unit is necessary. We provide the optional Camera Plate Unit. For details, refer to the
following section.
Options
(Units: mm)
Symbol Description
a Arm #5 Deck
b Arm #3 Deck
c Rotation center of the upper arm
3.4.3 WEIGHT and INERTIA Settings
The WEIGHT and INERTIA commands are for setting the load parameters of the Manipulator. These settings optimize the
Manipulator motion.
WEIGHT Setting
The WEIGHT command is for setting the load weight. The more the load weight increases, the more the speed and
acceleration/deceleration are reduced.
INERTIA Setting
The INERTIA command is for setting the inertia moment and the eccentricity of the load. The more the inertia moment
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
112
increases, the more the acceleration and deceleration of the Arm #6 are reduced. The more the eccentricity increases, the
more the acceleration and deceleration for the Manipulator movement are reduced.
To ensure that the Manipulator is functioning properly, keep the load (the sum of the weights of the hand and workpiece) and
the moment of inertia of the load within the rated values, and do not allow for eccentricity from the center of the Arm #6. If the
load or the inertia moment exceeds the ratings or if the load becomes eccentric, follow the steps below to set parameters.
WEIGHT Setting
INERTIA Setting
Setting parameters makes the operation of the Manipulator optimal, reduces vibration to shorten the operating time, and
improves the capacity for larger loads. This also works to curb any persistent vibration that may occur when the hand and
workpiece have a large moment of inertia.
You can also perform settings using the "Weight, Inertia, and Eccentricity/Offset Measurement Utility."
For details, refer to the following manual.
"Epson RC+ User's Guide - Weight, Inertia, and Eccentricity/Offset Measurement Utility"
The allowable load for C12 series Manipulators is up to 12 kg.
Due to the limitations of the moment and moment of inertia shown in the table below, the load (hand + workpiece) should also
meet these conditions.
Allowable Load
Joint Allowable moment
(GD
2
/4) Allowable Moment of Inertia
Joint #4 25.0 N·m (2.55 kgf·m)
0.70 kg·m
2
Joint #5 25.0 N·m (2.55 kgf·m)
0.70 kg·m
2
Joint #6 9.8 N·m (1.0 kgf·m)
0.20 kg·m
2
Moment
The moment indicates amount of torque applied on the joint in order to support the gravity on the load hand + workpiece). The
moment increases as weight of the load and amount of eccentricity increase. As this also increases the load applied on the joint,
make sure to keep the moment within the allowable value.
Moment of inertia
The moment of inertia indicates how difficult the load (hand + workpiece) to rotate when the Manipulator joint starts to rotate
(amount of inertia). The moment of inertia increases as weight of the load and amount of eccentricity increase. As this also
increases the load applied on the joint, make sure to keep the moment within the allowable value.
The moment M (Nm) and moment of inertia I (kgm
2
) when the volume of the load (hand + workpiece) is small can be
obtained by the following formula.
M (Nm) = m (kg) × L (m) × g (m/s
2
)
I (kgm
2
) = m (kg) × L2 (m)
m: Weight of load (kg)
L: Eccentricity of load (m)
g: Gravitational acceleration (m/s
2
)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
113
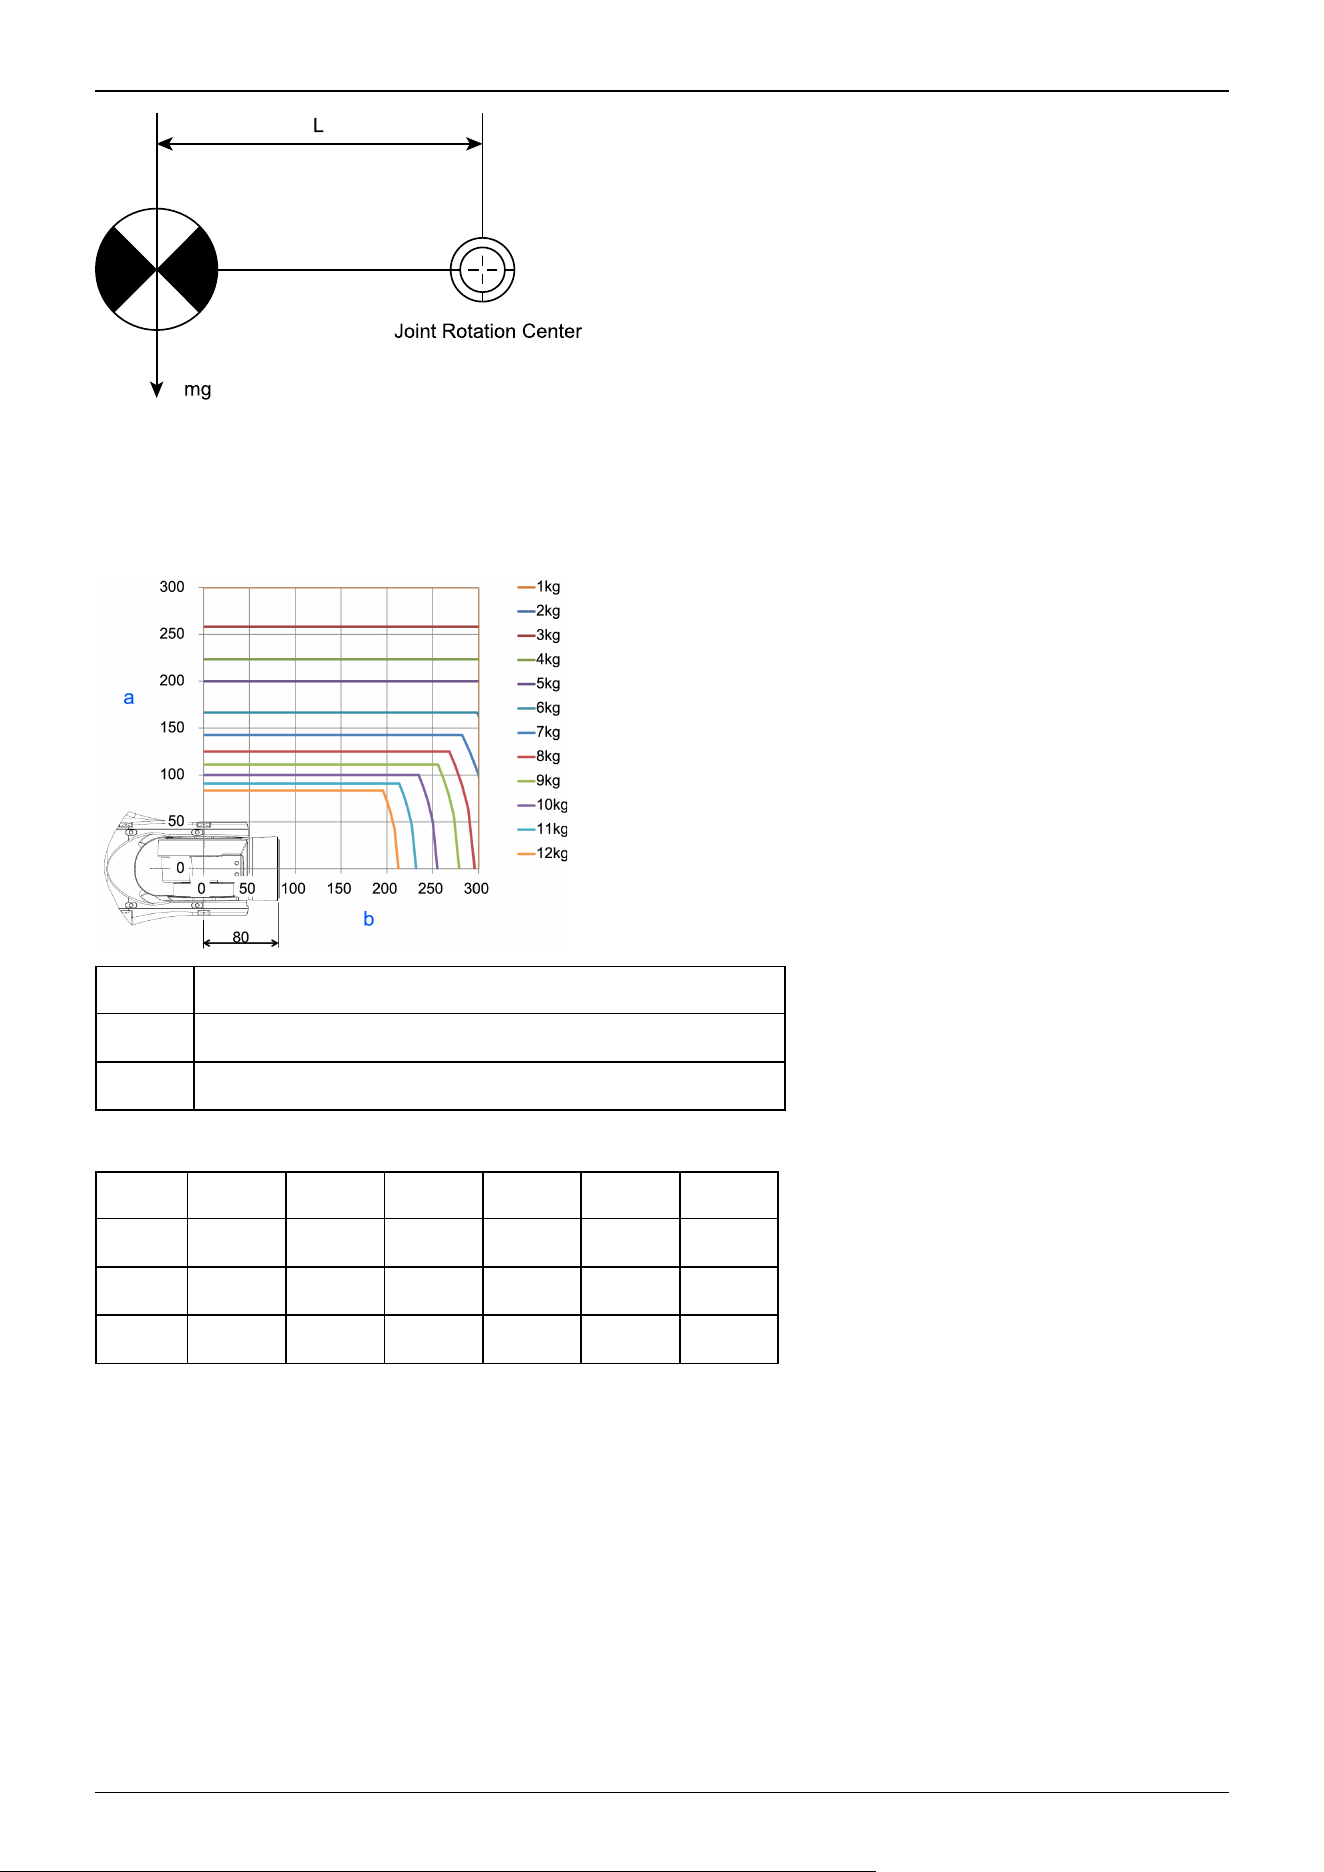
The figure below shows distribution of the center of gravity when the volume of the load (hand + workpiece) is small. Design
the hand so that the center of gravity is within the allowable moment. If the volume of the load is large, calculate the moment
and inertia moment by referring to the following section.
"INERTIA Setting - Calculating the Moment of Inertia"
Symbol Description
a Distance from the center of Arm #* rotation [mm]
b Center of gravity of load from the Arm #* rotation center [mm]
Max. Eccentricity of Load (Distance between the joint rotation center and the load’s center of gravity)
Joint 1 kg 3 kg 5 kg 8 kg 10 kg 12 kg
#4 300 mm 300 mm 300 mm 296 mm 255 mm 213 mm
#5 300 mm 300 mm 300 mm 296 mm 255 mm 213 mm
#6 300 mm 258 mm 200 mm 125 mm 100 mm 83 mm
When calculating the critical dimension of the load using the allowable moment and inertia moment, the calculated value
represents a distance from the Arm #6 rotation center, not the distance from the flange. To calculate the distance from the
flange to the load’s center of gravity, subtract the distance from the center of the Arm #5 rotation center to the flange (=80 mm)
as shown in the example below.
Example: Calculation of the critical dimension of the load (A) when the load is 12 kg.
Center of gravity by the allowable moment control: 25.0 N·m/(12 kg × 9.8 m/s
2
) = 0.212 m = 212 mm
Center of gravity by the allowable inertia moment control: (0.70 kgm
2
/12 kg)1/2 = 0.241 m = 241 mm
Due to the allowable moment control, center of gravity for the load limit is 212 mm from the Arm #5 rotation center.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
114
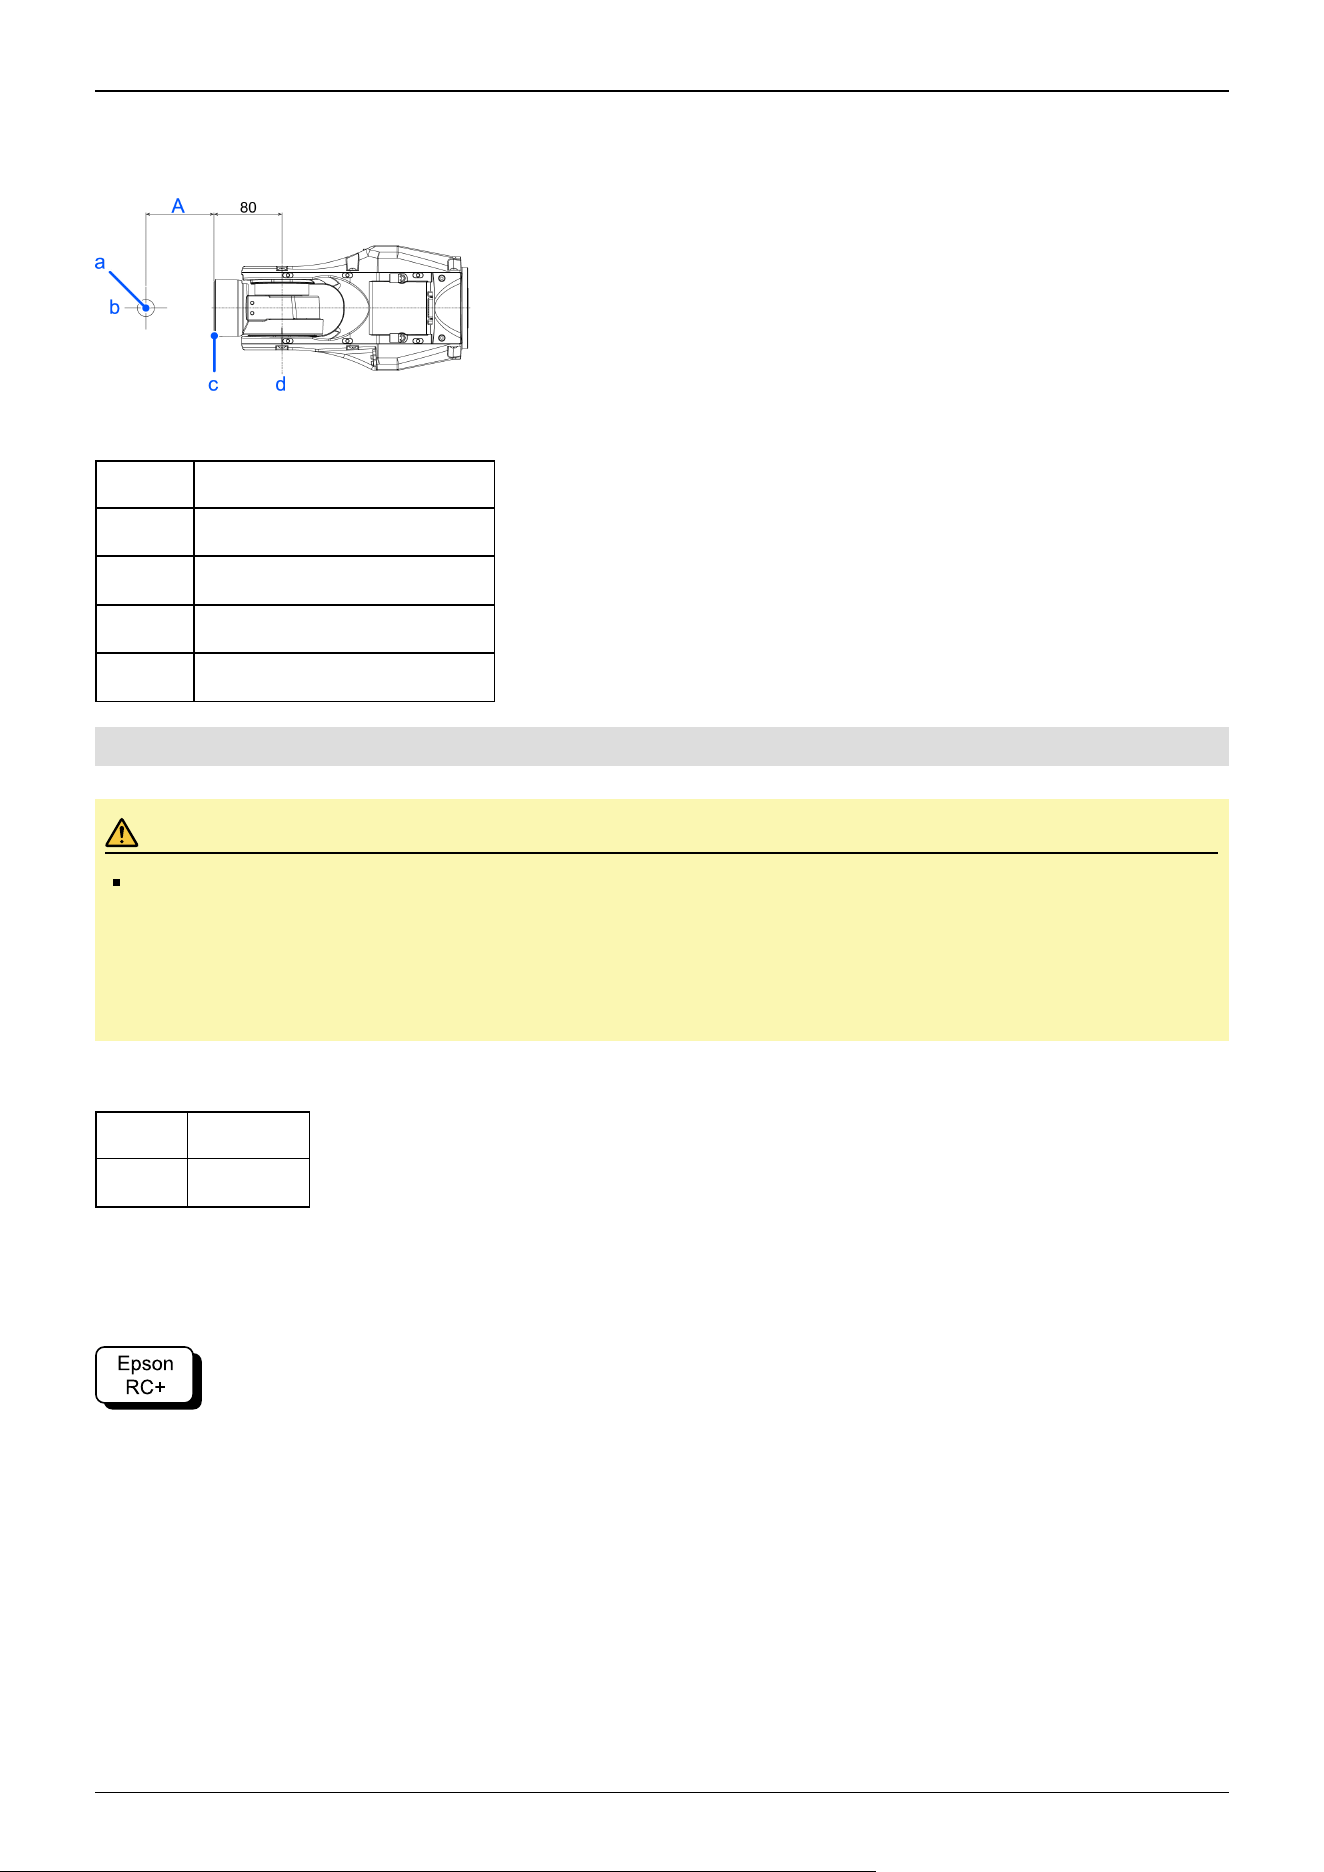
Distance from the flange to the center of gravity for the load limit A = 212 mm - 80 mm = 132 mm
Critical Dimension of Load
(Units: mm)
Symbol Description
a Load center of gravity position
b Arm #6 rotation center
c Flange
d Arm #5 rotation center
3.4.3.1 WEIGHT Setting
CAUTION
Set the total weight of the hand and the workpiece smaller than the maximum payload. The C12 series
Manipulators can operate without limitations on the condition unless and until the load exceeds this maximum
payload. Always set the Weight parameters of the WEIGHT command according to the load. Setting a value
smaller than the actual weight may cause errors or impact that not only impair full functionality but also
shorten the life of the mechanical components.
The acceptable weight capacity (hand + workpiece) for C12 series Manipulators is as follows:
Rated Maximum
3 kg 12 kg
Change the setting of the Weight parameter according to the load. After changing the Weight parameter setting, the maximum
acceleration/deceleration and speed of the robot system is set automatically.
Setting method of Weight parameters
Select [Tools]-[Robot Manager]-[Weight] panel and set the value in [Weight:]. You may also execute the Weight command
from [Command Window].
Load on the Manipulator
Mounting location of the load
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
115
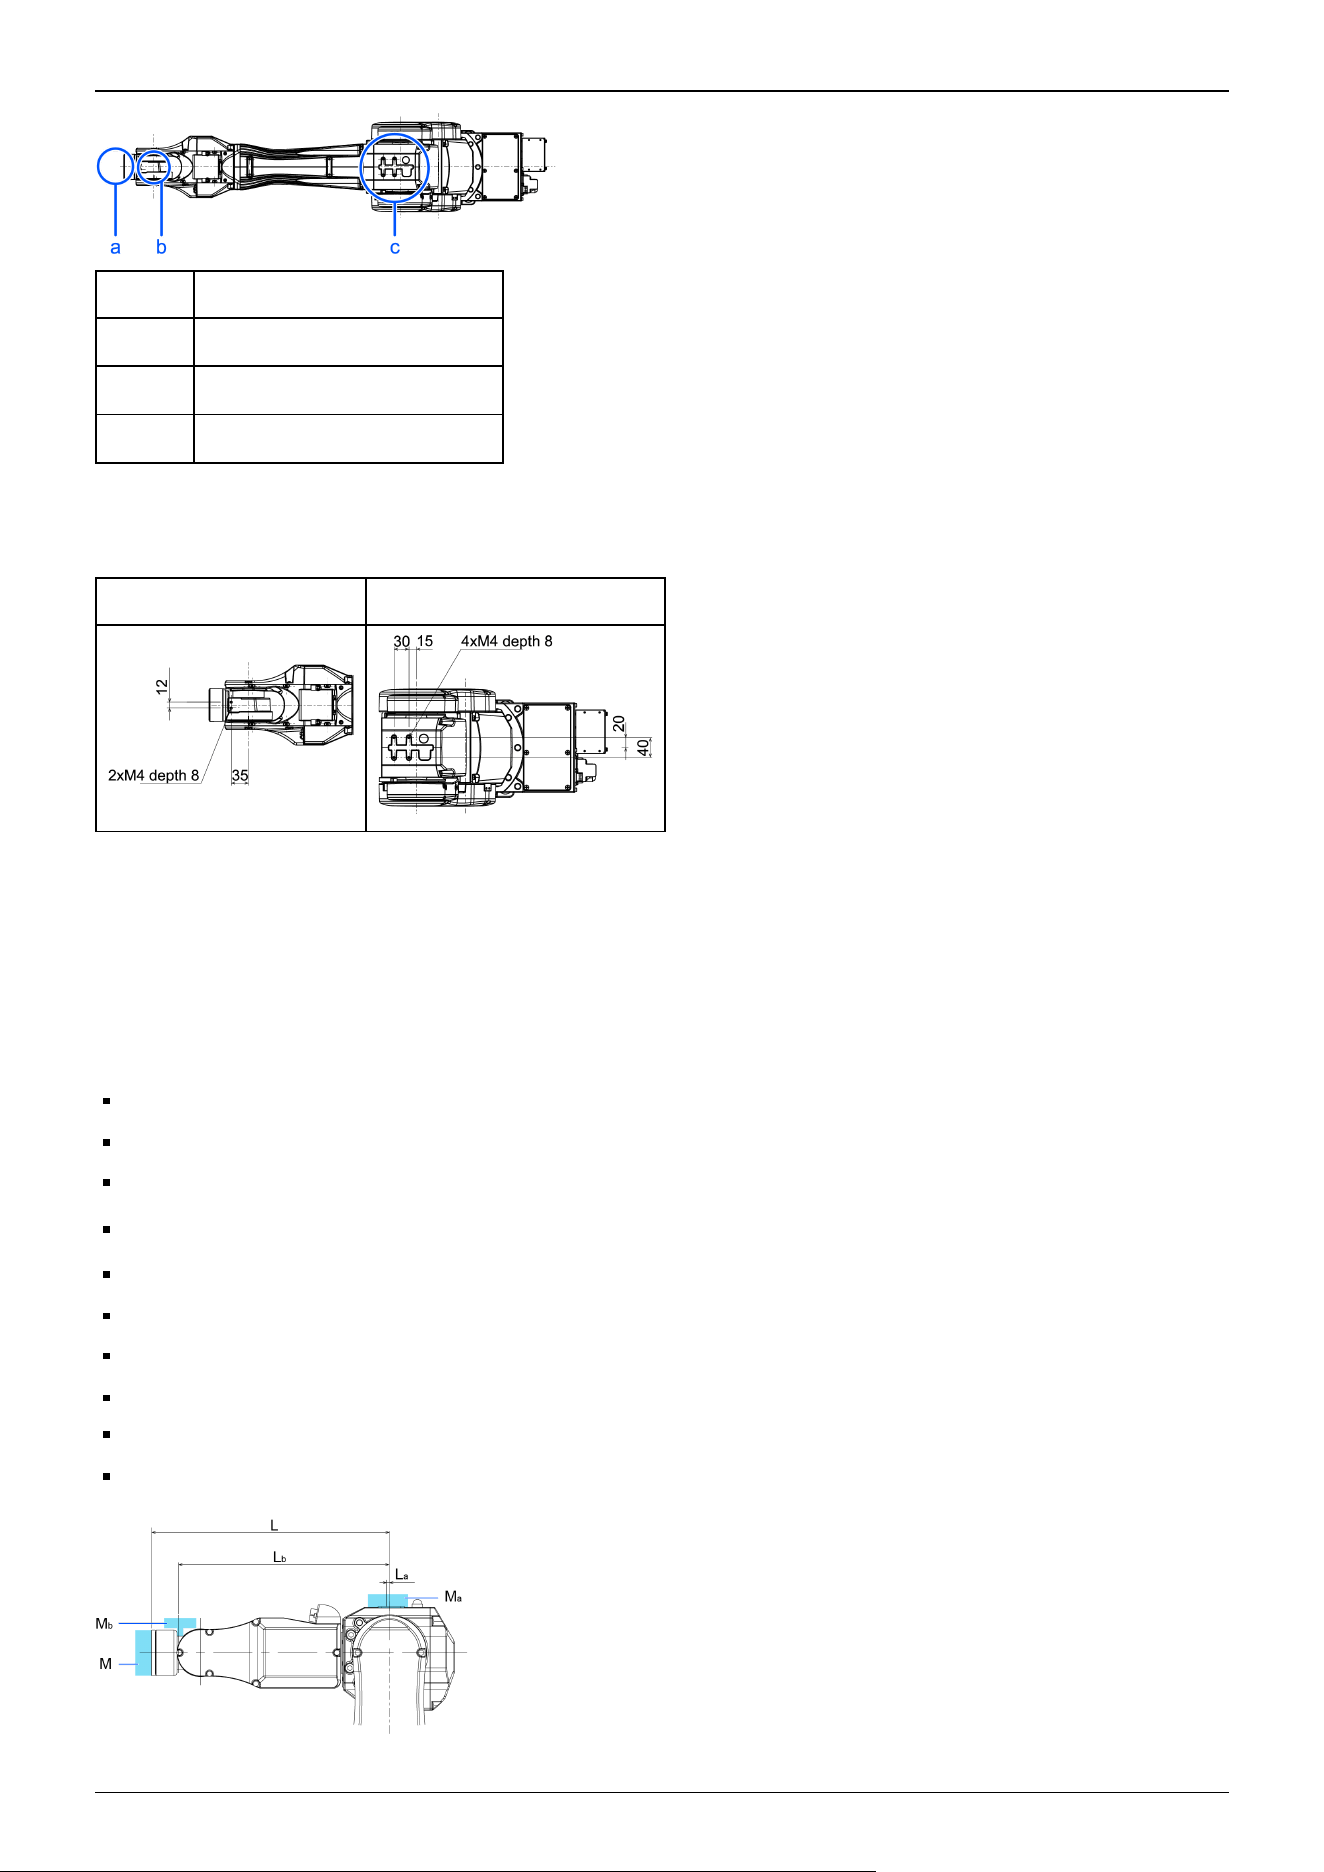
Symbol Description
a Load on the fore end of Arm #6
b Arm #5 deck
c Arm #3 deck
Deck detailed
(Units: mm)
Arm #5 deck Arm #3 deck
When you attach the equipment to the decks on the upper arm, convert its weight into equivalent weight assuming that the
equipment is attached to the end of the Arm #6. Then, this equivalent weight added to the load will be a Weight parameter.
Calculate the Weight parameter by using the formula below and enter the value.
Weight Parameter Formula
Weight parameter = M
w
+ W
a
+ W
b
M
w
: Payload on the fore end of Arm #6 (kg)
W
a
: Equivalent weight of the Arm #3 deck (kg)
W
b
: Equivalent weight of the Arm #5 deck (kg)
W
a
=M
a
(L
a
)
2
/(L)
2
W
b
=M
b
(L
b
)
2
/(L)
2
M
a
: Weight of the air valve on the Arm #3 deck (kg)
M
b
: Weight of the camera on the Arm #5 deck (kg)
L: Length of the upper arm (315 mm)
L
a
: Distance between the Joint #3 and the center of gravity of the air valve on the Arm #3 deck (mm)
L
b
: Distance between the Joint #3 and the center of gravity of the camera on the Arm #5 deck (mm)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
116
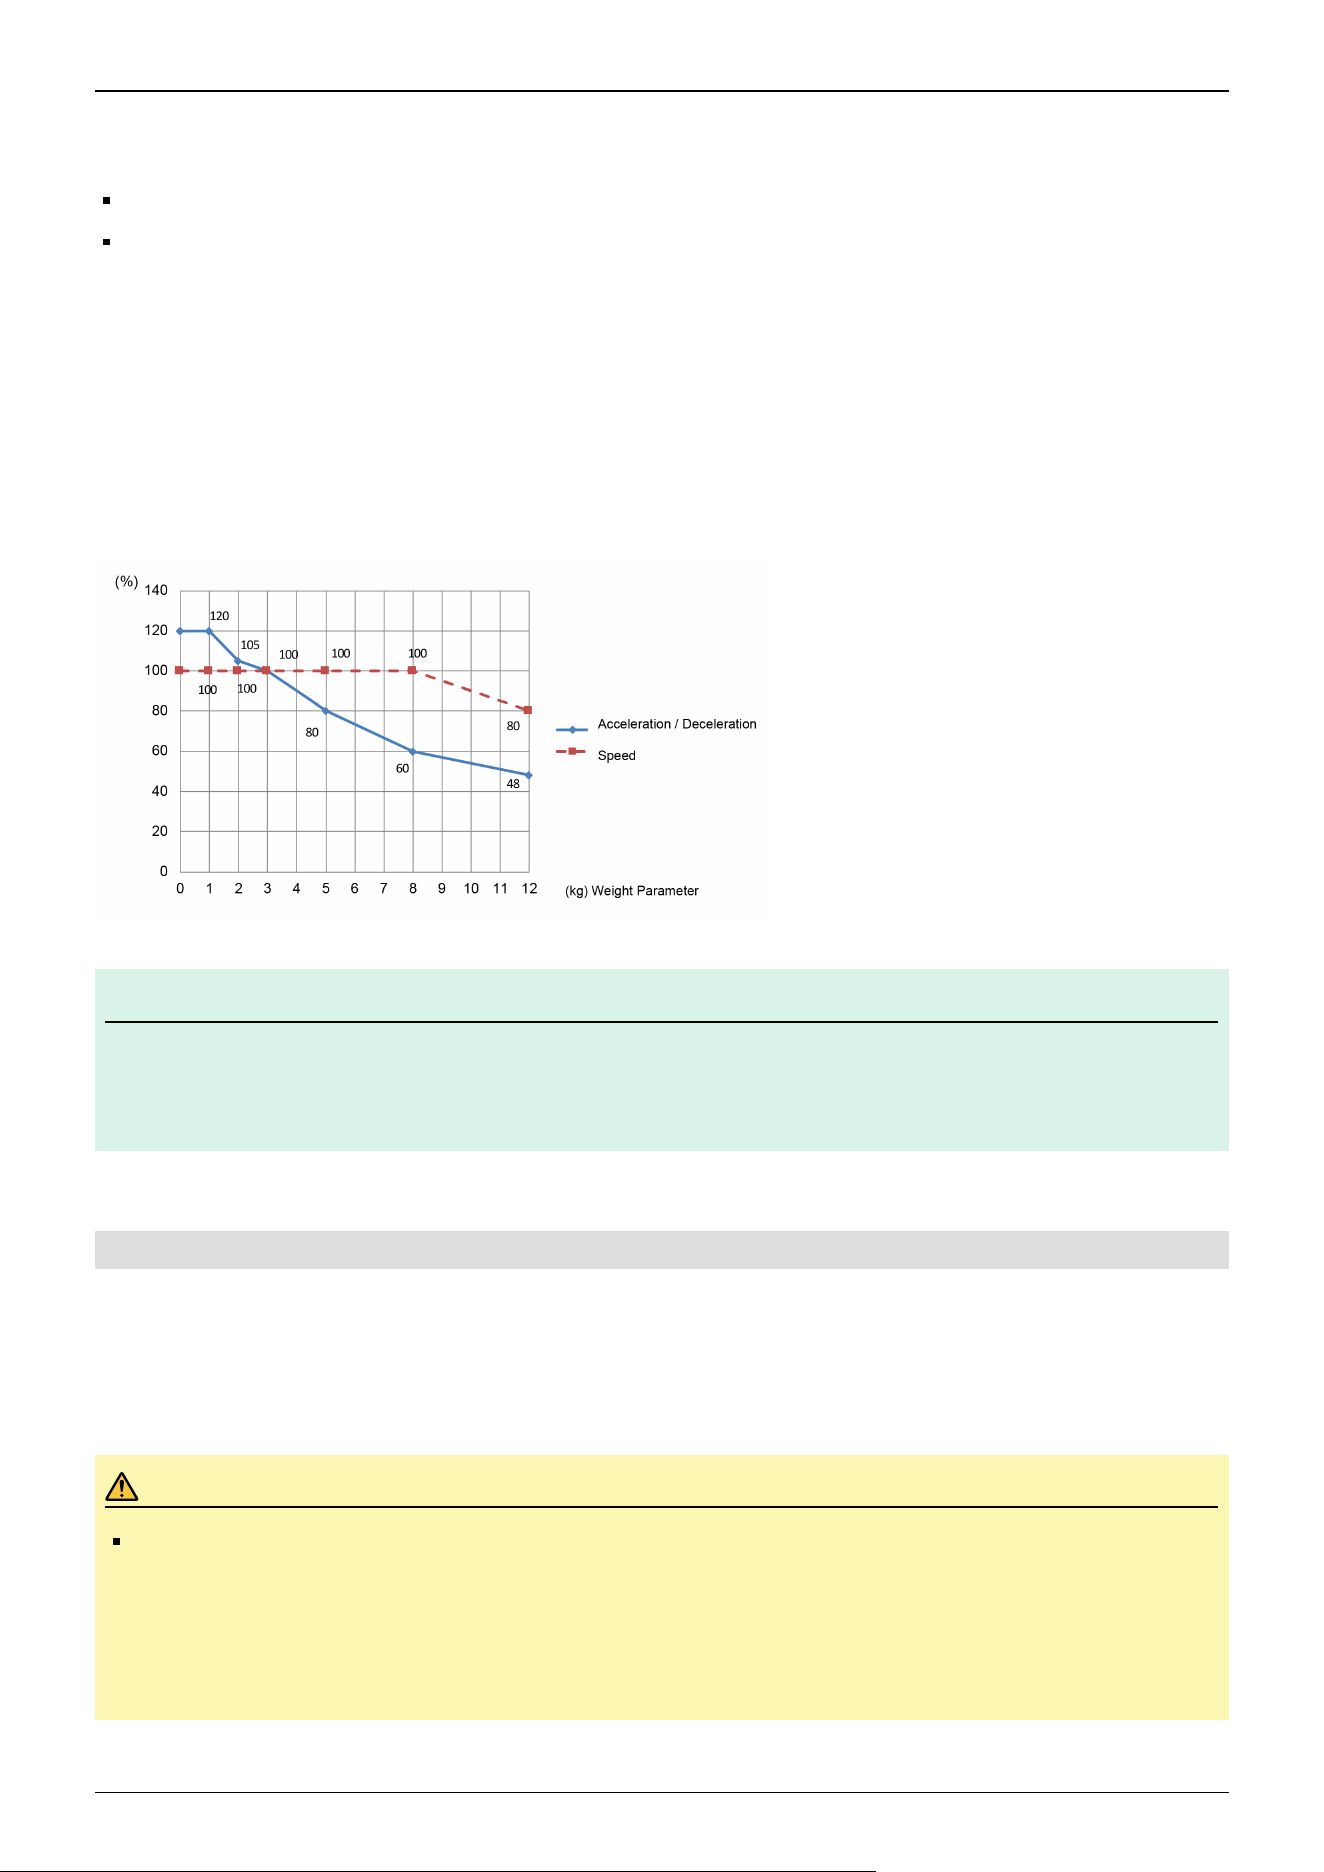
[Example] When the following loads apply to C12-C1401** (C12XL) which fore end of the Arm #6 is 730 mm (L) away from
the Joint #3 and payload (M
w
) is 5 kg:
Load on the Arm #3 deck is 1.5 kg (M
a
). The deck is 0 mm (L
a
) away from the Joint #3.
Load on the Arm #5 deck is 1.0 kg (M
b
). The deck is 690 mm (L
b
) away from the Joint #3.
W
a
=1.5 × 0
2
/730
2
=0
W
b
=1.0 × 690
2
/730
2
=0.89 → 0.9 (round up)
M
w
+W
a
+W
b
=5+0+0.9=5.9
Enter "5.9" for the Weight parameter.
Automatic speed setting by Weight parameter
The percentage in the graph is based on the speed at rated weight (3 kg) as 100%.
KEY POINTS
Maximum AccelS setting value varies depending on Weight setting value. For details, refer to the following
section.
C12 Specifications
3.4.3.2 INERTIA Setting
Moment of Inertia and INERTIA Setting
The moment of inertia is a quantity that expresses how hard it is for an object to turn, and it is expressed in terms of values for
the moment of inertia, inertia, or GD
2
. When a hand or other object is attached to the Arm #6 for operation, the moment of
inertia of the load must be taken into consideration.
CAUTION
The moment of inertia of the load (hand + workpiece) must be 0.2 kg·m
2
or less.
The C12 Manipulators are not designed to work with a moment of inertia exceeding 0.2 kg·m
2
. Always set the
value corresponding to the moment of inertia. Setting a parameter value that is smaller than the actual
moment of inertia may cause errors or impact, may prevent the Manipulator from working at full functionality,
and may shorten the lifespan of mechanical parts.
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
117
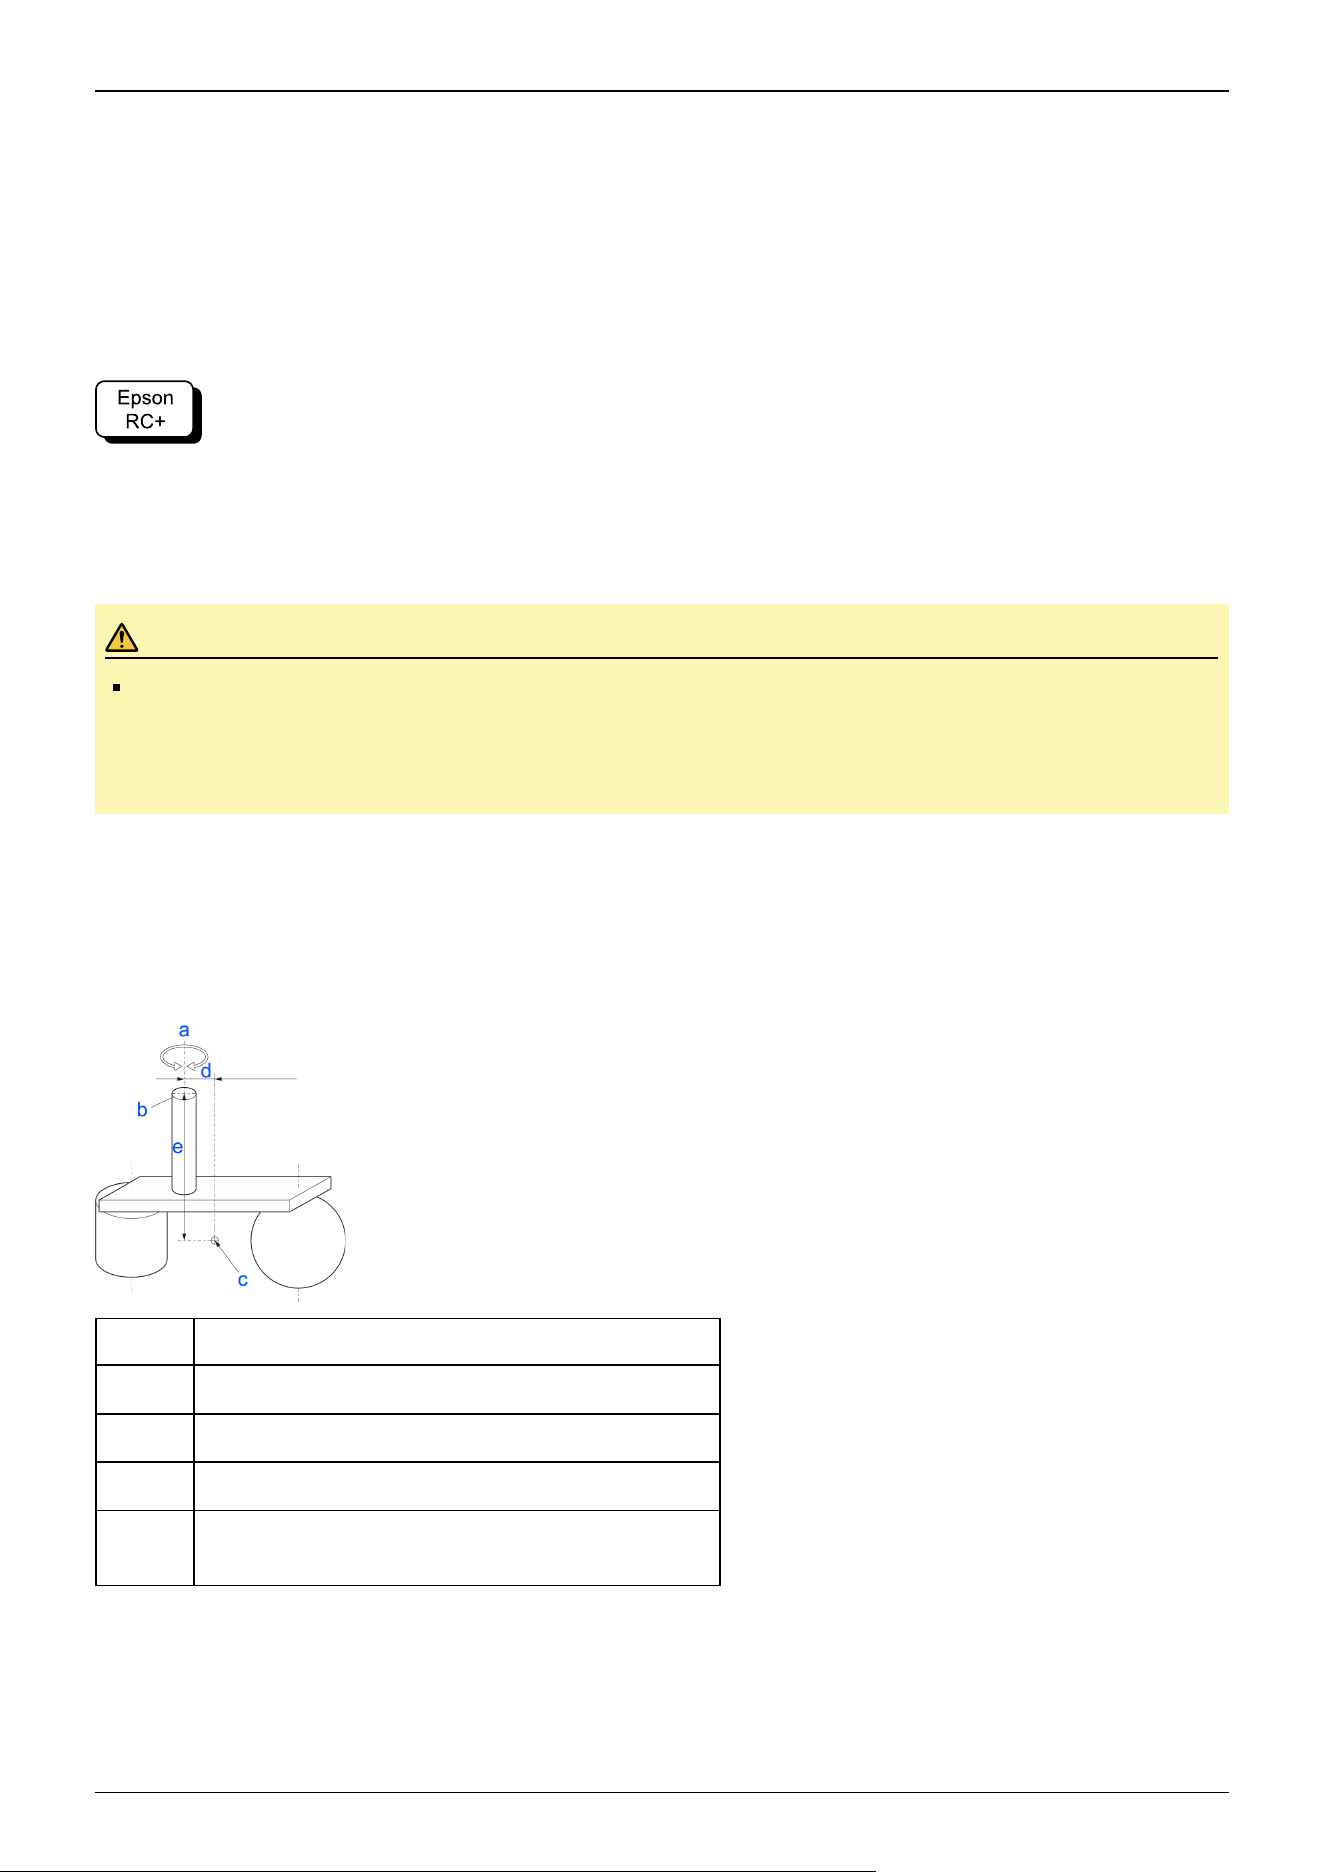
The allowable moment of inertia of a load for C12 Manipulators is 0.03 kg·m
2
at the default rating and 0.2 kg·m
2
at the
maximum. Change the setting of the moment of inertia according to the inertia moment of the load using the INERTIA
command. After the setting is changed, the maximum acceleration/deceleration of Arm #6 that corresponds to the "Inertia"
value is corrected automatically.
Moment of Inertia of Load Attached to Arm #6
The moment of inertia of the load (hand + workpiece) attached to the Arm #6 can be set by the "Inertia" parameter in the
Inertia statement.
Go to [Tools] - [Robot Manager] - [Inertia] panel, and enter the value in [Inertia]. This can also be set using the Inertia
statement in [Command Window].
Eccentricity and INERTIA Setting
CAUTION
The eccentricity of the load (hand + workpiece) must be 300 mm or less. The C12 series Manipulators are not
designed to work with eccentricities exceeding 300 mm. Always set the value based on the eccentricity.
Setting the eccentricity parameter to a value smaller than the actual eccentricity may cause errors or impact
that not only impair full functionality but also shorten the life of the mechanical components.
The allowable eccentricity of load for C12 Manipulators is 50 mm at the default rating and 300 mm at the maximum. When the
load eccentricity exceeds the rating, change the setting for the eccentricity parameter in Inertia statement. After the setting is
changed, the maximum acceleration/deceleration of the Manipulator that corresponds to the "Eccentricity" is corrected
automatically.
Eccentricity
Symbol Description
a Rotation axis
b Flange
c Load center of gravity position
d, e
Eccentricity (300 mm or less)
To set the parameter, enter the larger value of "d" or "e".
Eccentricity of Load Attached to Arm #6
The eccentricity of the load (hand + workpiece) attached to the Arm #6 can be set by the "Eccentricity" parameter in the Inertia
statement.
Enter the larger value of either "d" or "e" in the figure above to [Eccentricity].
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
118
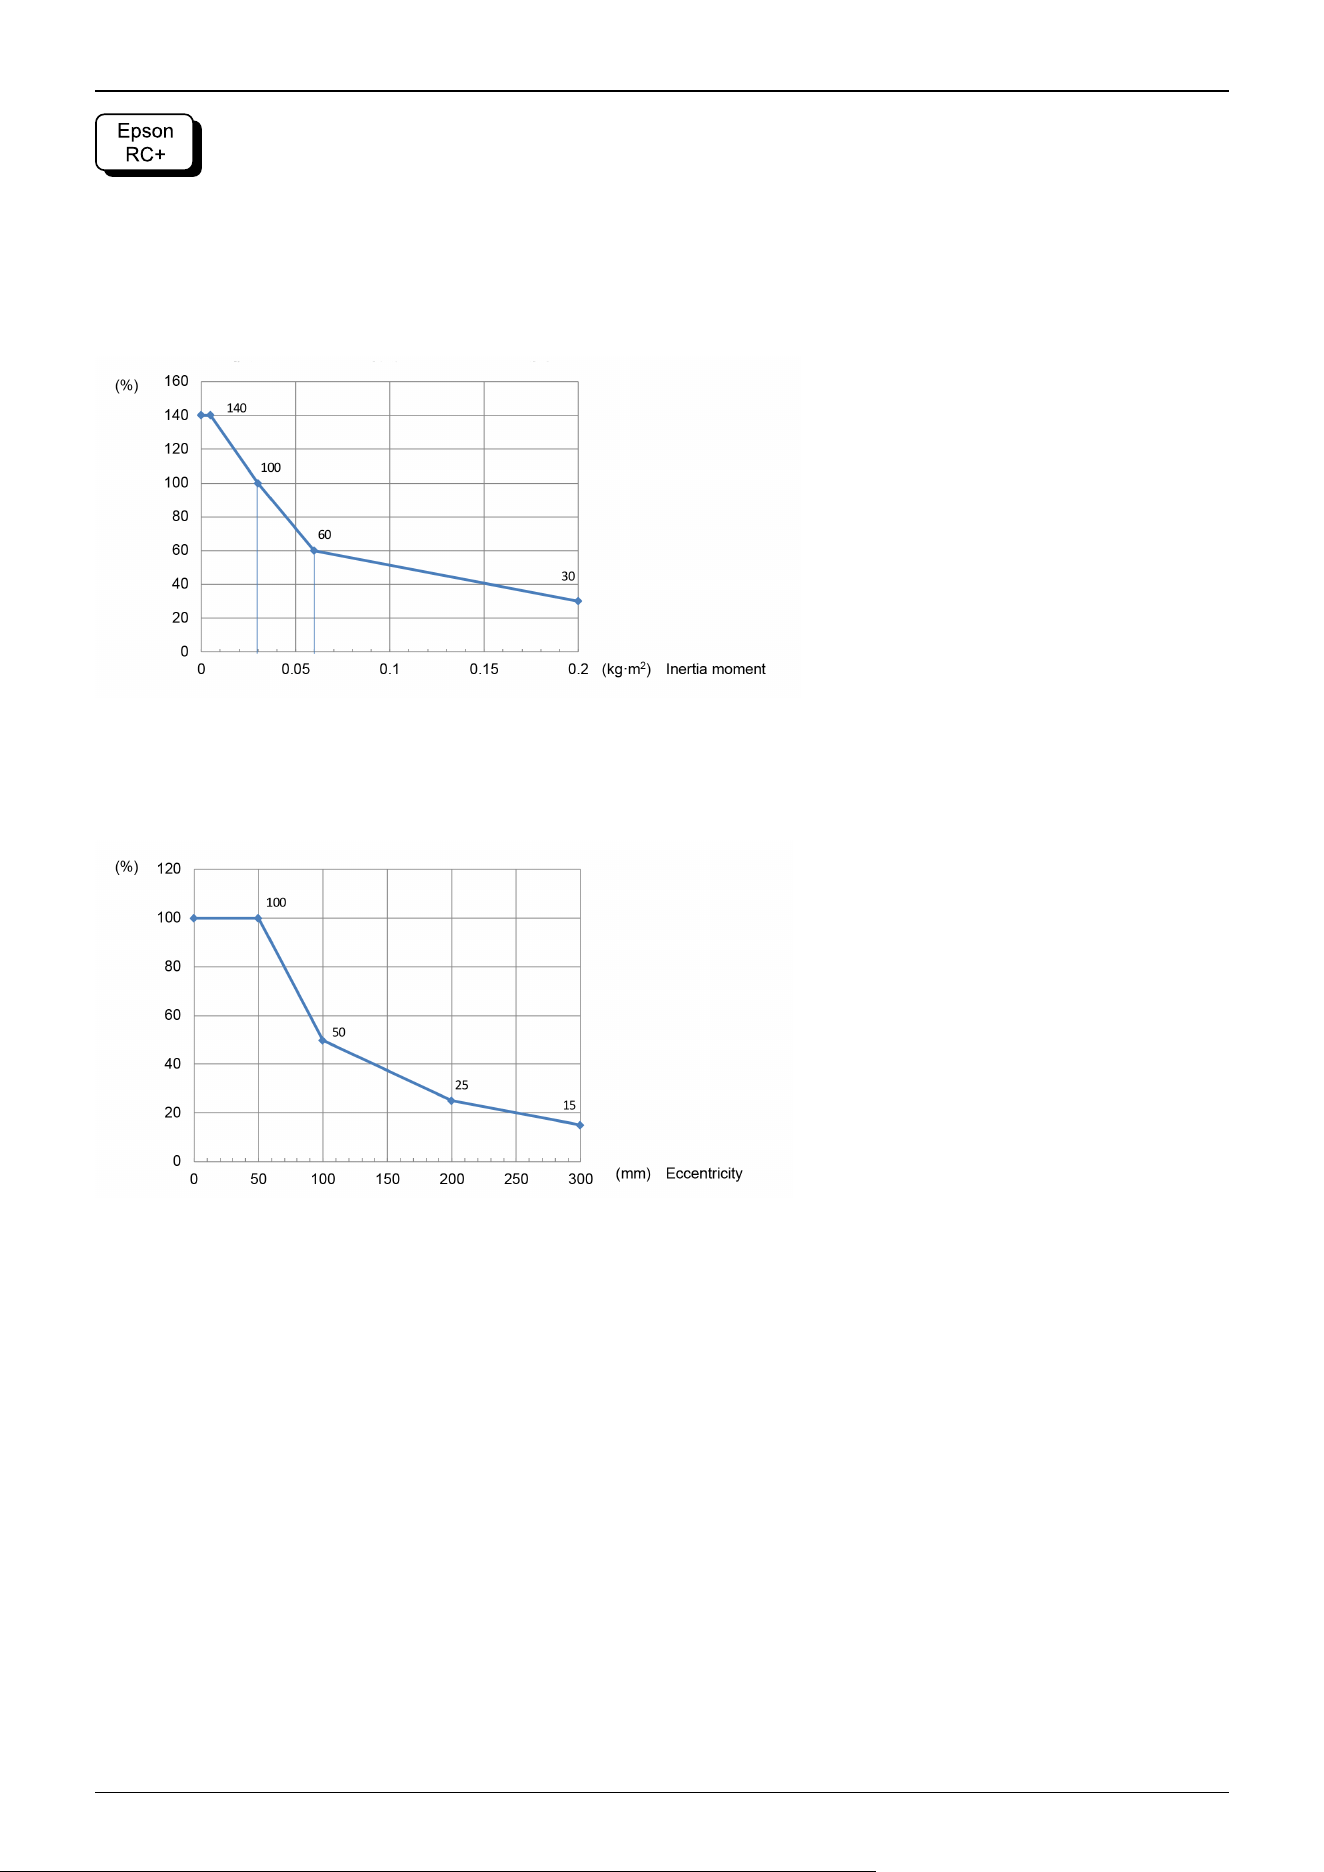
Go to [Tools] - [Robot Manager] - [Inertia] panel, and enter the value in [Eccentricity]. This can also be set using the Inertia
statement in [Command Window].
Automatic Acceleration/Deceleration Correction at INERTIA (Eccentricity) Setting
Automatic setting by inertia moment setting
* The percentages on the graph are ratios based on 100% as the acceleration/deceleration at the rated (0.03 kg·m
2
) setting.
Automatic setting by eccentricity setting
* The percentages on the graph are ratios based on 100% as the acceleration/deceleration at the rated (50 mm) setting.
Calculating the Moment of Inertia
An example of calculating the moment of inertia of a load (hand holding a workpiece) is shown below.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
119
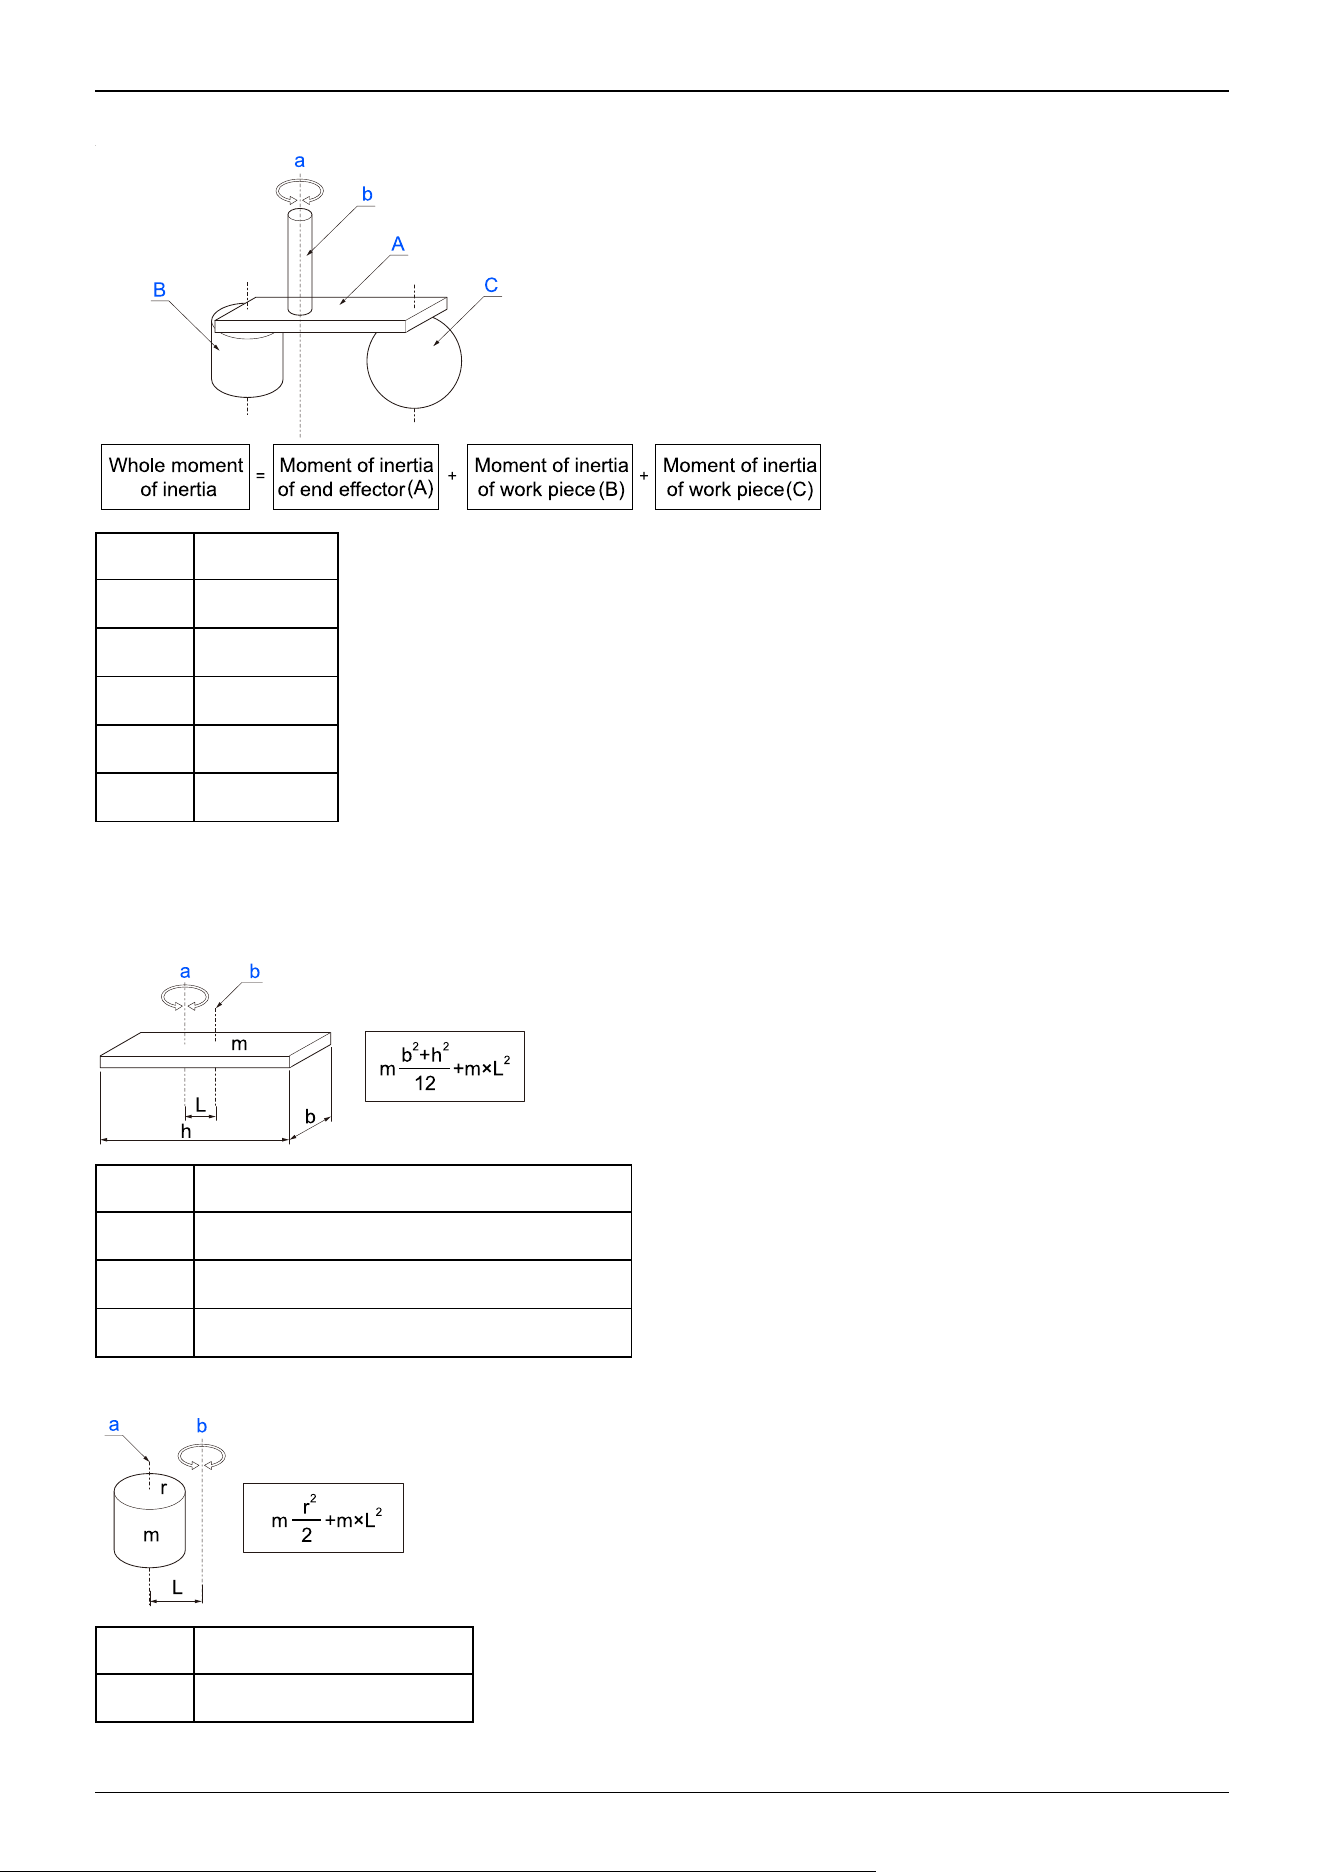
The moment of inertia of the entire load is calculated by the sum of (A), (B), and (C).
Symbol Description
a Rotation axis
b Shaft
A Hand
B Workpiece
C Workpiece
The methods for calculating the moment of inertia for (A), (B), and (C) are shown below. Use the moment of inertia of these
basic shapes as a reference to find the moment of inertia of the entire load.
(A) Moment of inertia of a rectangular parallelepiped
Symbol Description
a Rotation axis
b Center of gravity of rectangular parallelepiped
m Weight
(B) Moment of inertia of a cylinder
Symbol Description
a Center of gravity of cylinder
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
120
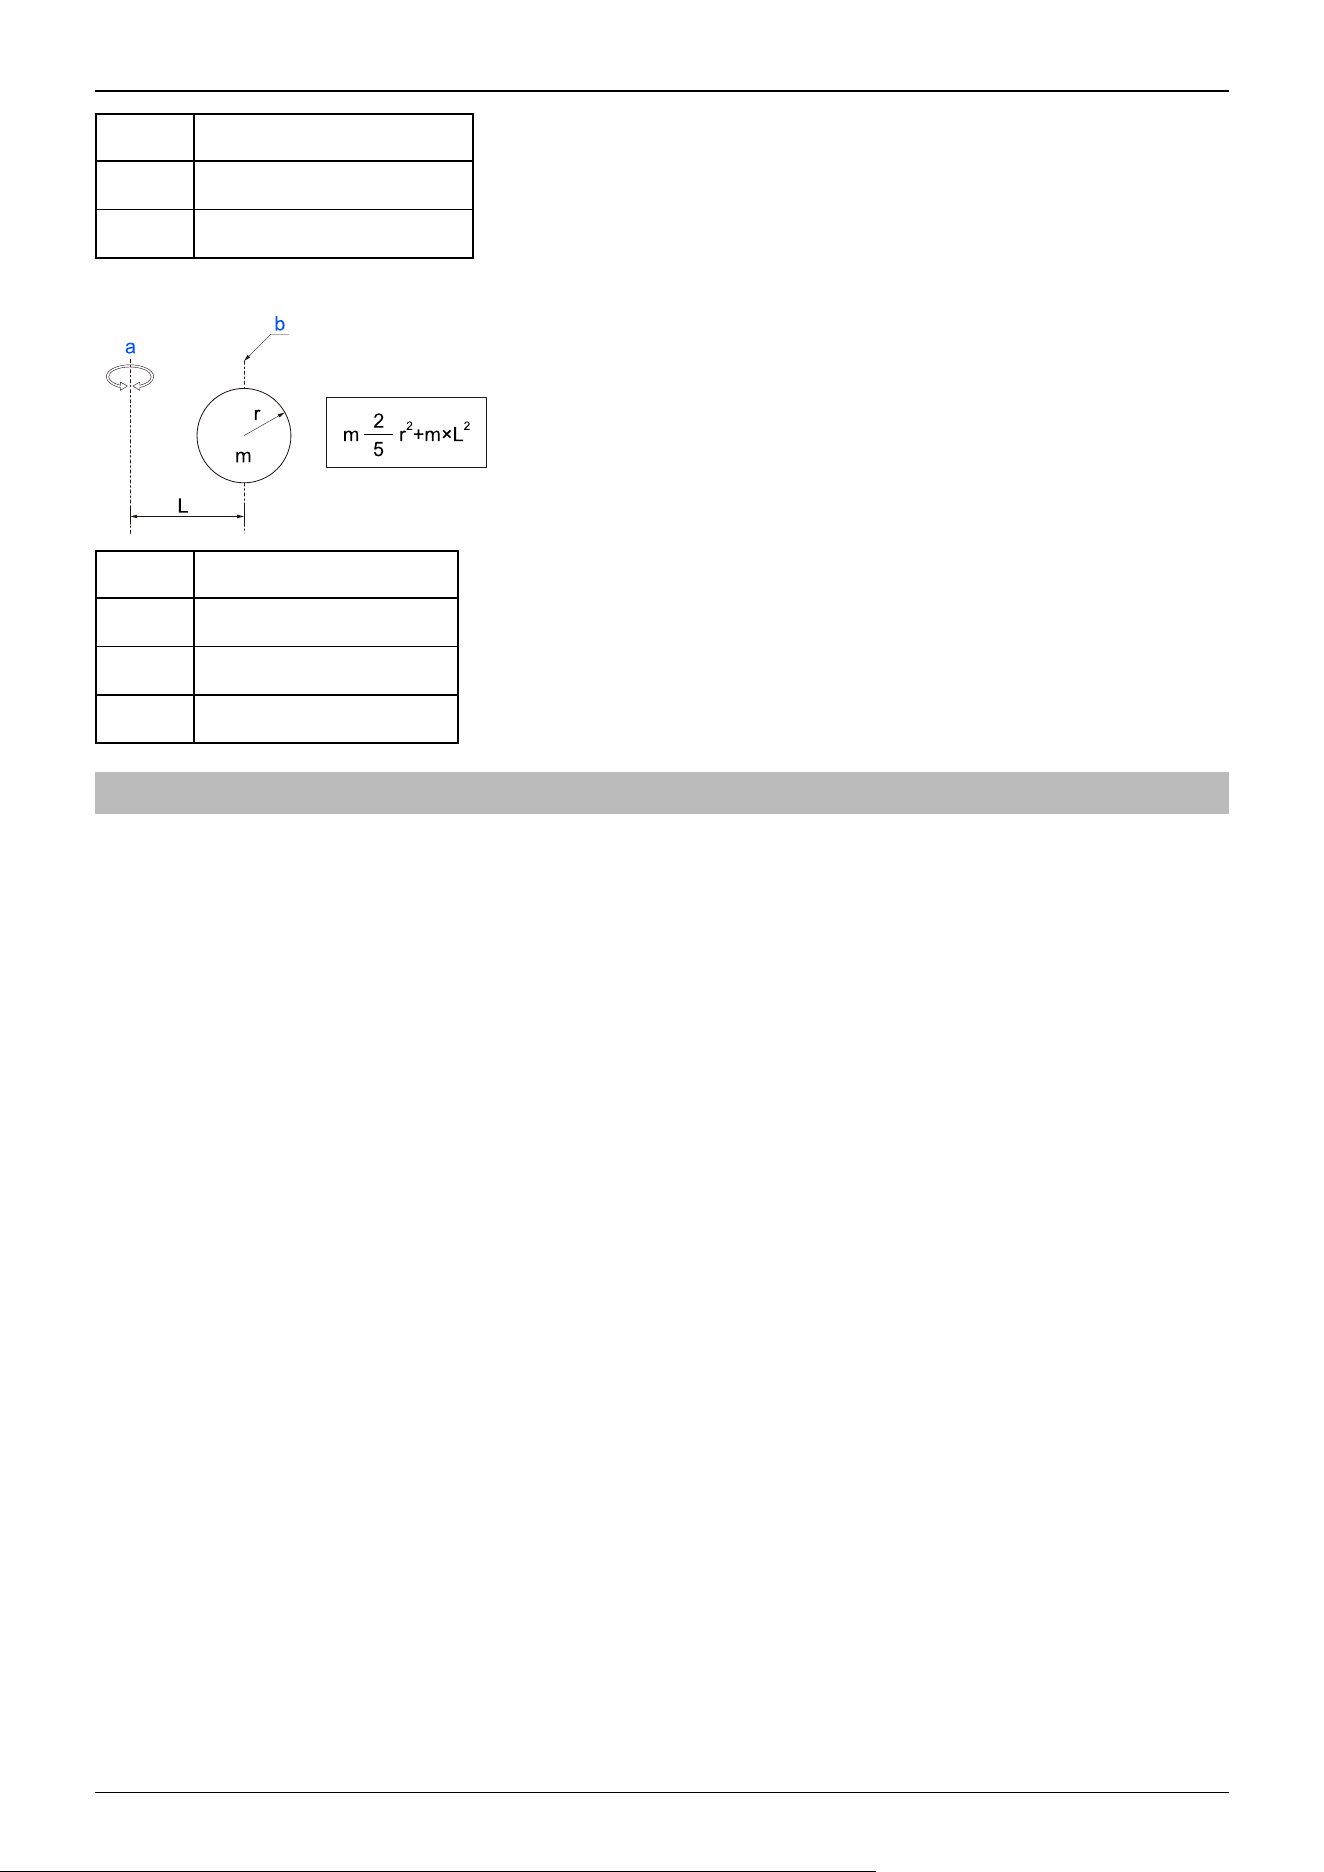
Symbol Description
b Rotation axis
m Weight
(C) Moment of inertia of a sphere
Symbol Description
a Rotation axis
b Center of gravity of sphere
m Weight
3.4.4 Safety Information for Auto Acceleration
The speed and acceleration/deceleration of the Manipulator motion are automatically optimized according to the values of
WEIGHT and INERTIA and the Manipulator’s postures.
WEIGHT Setting
The speed and acceleration/deceleration of the Manipulator are controlled according to the load weight set by the WEIGHT
command. The more the load weight increases, the more the speed and acceleration/deceleration are reduced to prevent
residual vibration.
INERTIA Setting
The acceleration/deceleration of Arm #6 are controlled according to the inertia moment set by the INERTIA command. The
acceleration/deceleration of the whole Manipulator are controlled according to the eccentricity set by the INERTIA command.
The more the inertia moment and eccentricity of the load increase, the more the acceleration/ deceleration are reduced.
Auto Acceleration/Deceleration According to Manipulator’s Posture
The acceleration/deceleration are controlled according to the Manipulator’s posture. When the Manipulator extends its arms or
when the movement of the Manipulator produces vibration frequently, the acceleration/deceleration are reduced.
Set appropriate values for WEIGHT and INERTIA so that the Manipulator operation is optimized.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
121
3.5 Work Envelope
WARNING
Do not operate the Manipulator with the mechanical stop removed. Removing the mechanical stop is
extremely dangerous because the Manipulator may move to a position outside its normal work envelope.
CAUTION
When restricting the work envelope for safety reasons, be sure to make settings using both the pulse range
and mechanical stop.
The work envelope is preset at the factory as explained in the following section. This is the maximum work envelope of the
Manipulator.
Standard Work Envelope
The work envelope can be set by one of the following three methods.
1. Setting by pulse range (for each joint)
2. Setting by mechanical stops
3. Setting the rectangular range in the XY coordinate system of the Manipulator
To limit the work envelope for layout efficiency or safety reasons, make the settings as explained in the following sections.
Work Envelope Setting by Pulse Range (for Each Joint)
Setting the Work Envelope by Mechanical Stops
Restriction of Manipulator Operation by Joint Angle Combination
Coordinate System
3.5.1 Work Envelope Setting by Pulse Range (for Each Joint)
Pulses are the basic unit of Manipulator motion. The motion range (work envelope) of the Manipulator is set by the pulse
lower limit value and pulse upper limit value (pulse range) for each joint. Pulse values are read from the encoder output of the
servomotor.
Be sure to set the pulse range within the mechanical stop range.
KEY POINTS
The Arm #1 and #4 do not have a mechanical stop.
Once the Manipulator receives a motion command, it checks whether the target position specified by the
command is within the pulse range before operating. If the target position is outside of the pulse range that
was set, an error occurs and the Manipulator does not move.
Go to [Tools] - [Robot Manager] - [Range] panel, and make the setting. This can also be set using the Range statement in
[Command Window].
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
122
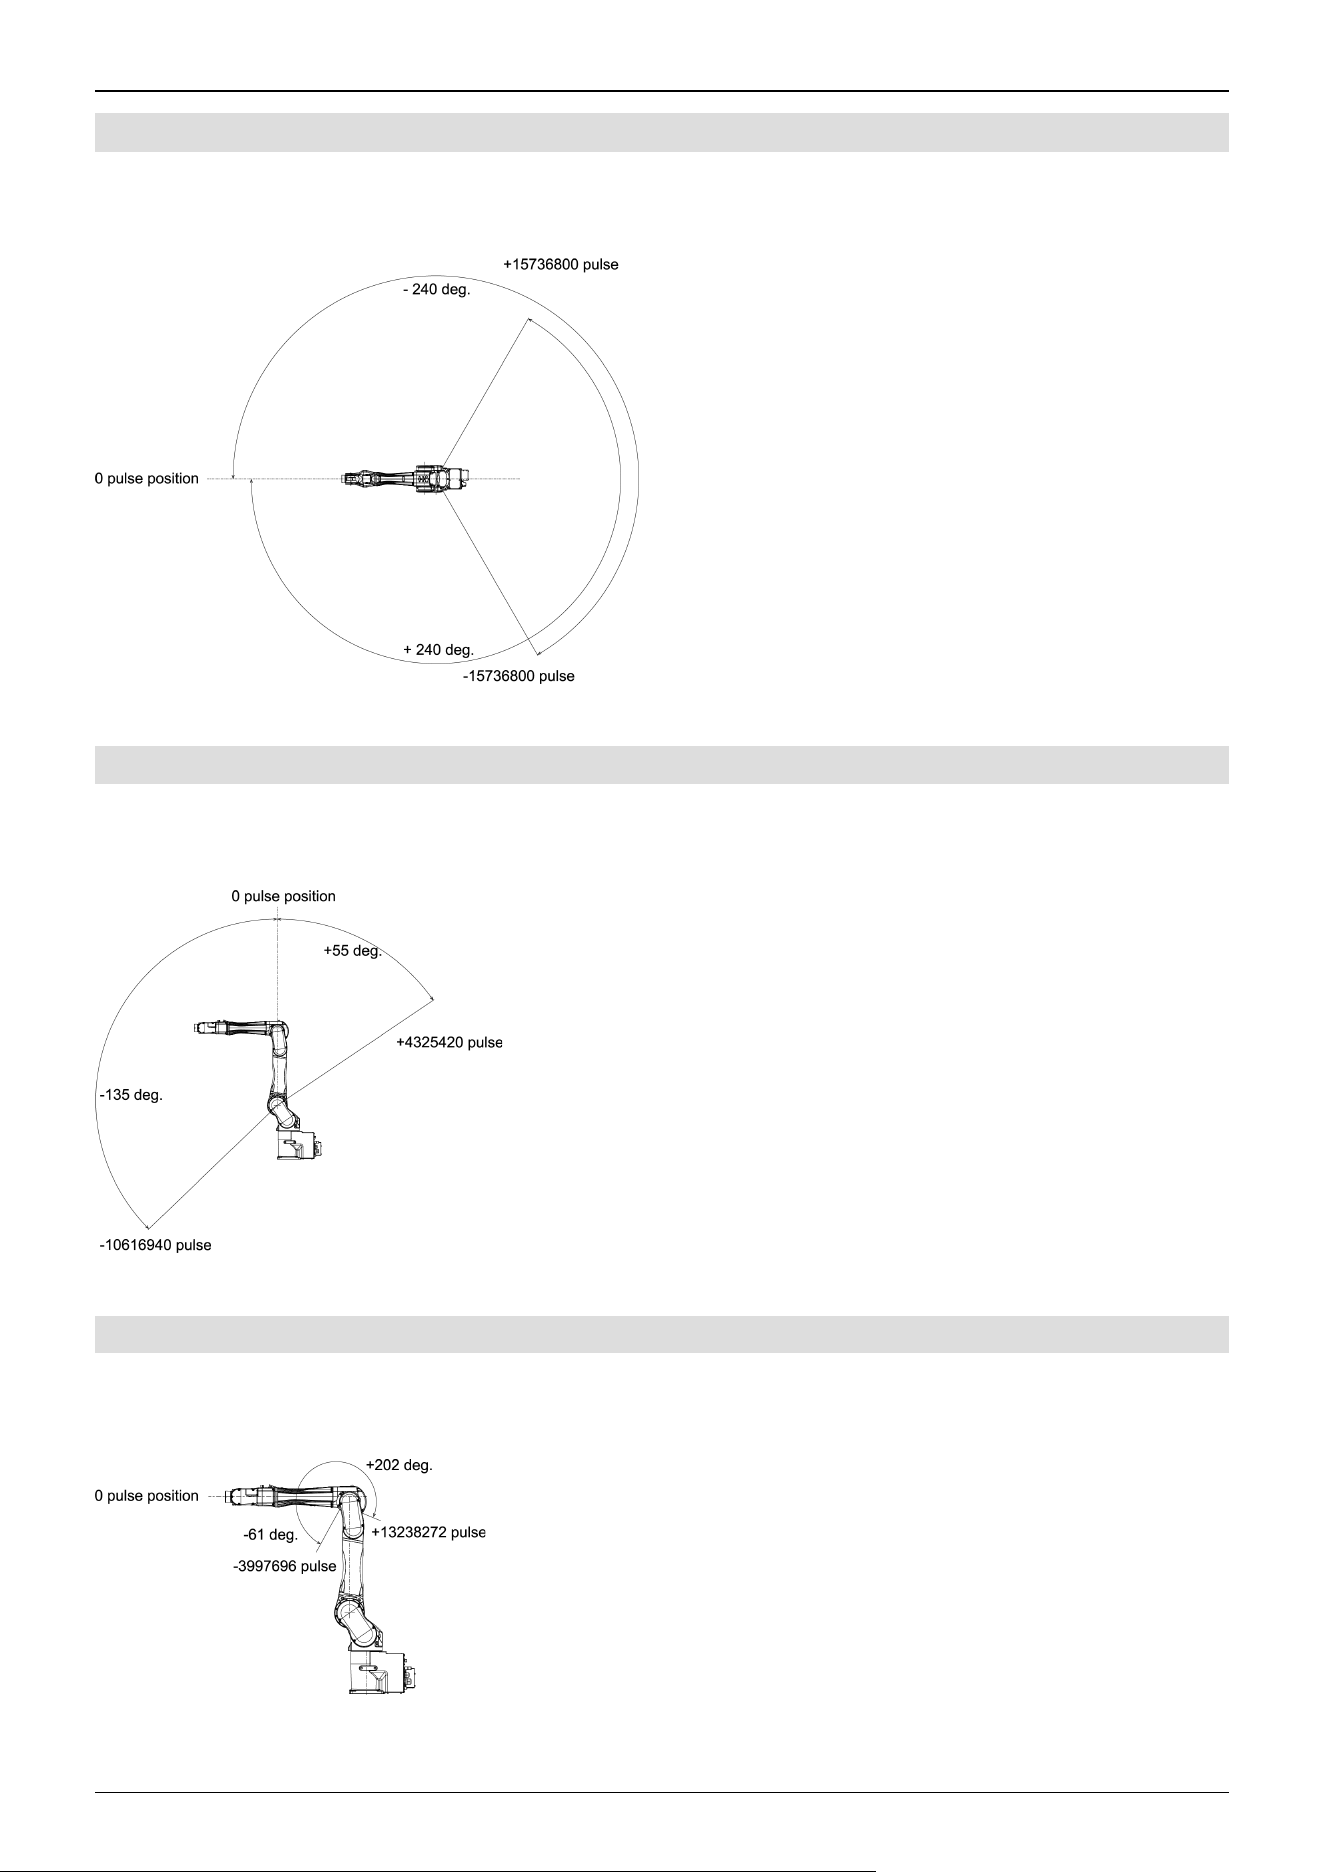
3.5.1.1 Joint #1 Maximum Pulse Range
With the 0 pulse as a starting point, the counterclockwise pulse value is defined as positive (+), and the clockwise pulse value
is defined as negative (-).
3.5.1.2 Joint #2 Maximum Pulse Range
With the 0 pulse as a starting point, the clockwise pulse value is defined as positive (+), and the counterclockwise pulse value
is defined as negative (-).
3.5.1.3 Joint #3 Maximum Pulse Range
With the 0 pulse as a starting point, the clockwise pulse value is defined as positive (+), and the counterclockwise pulse value
is defined as negative (-).
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
123
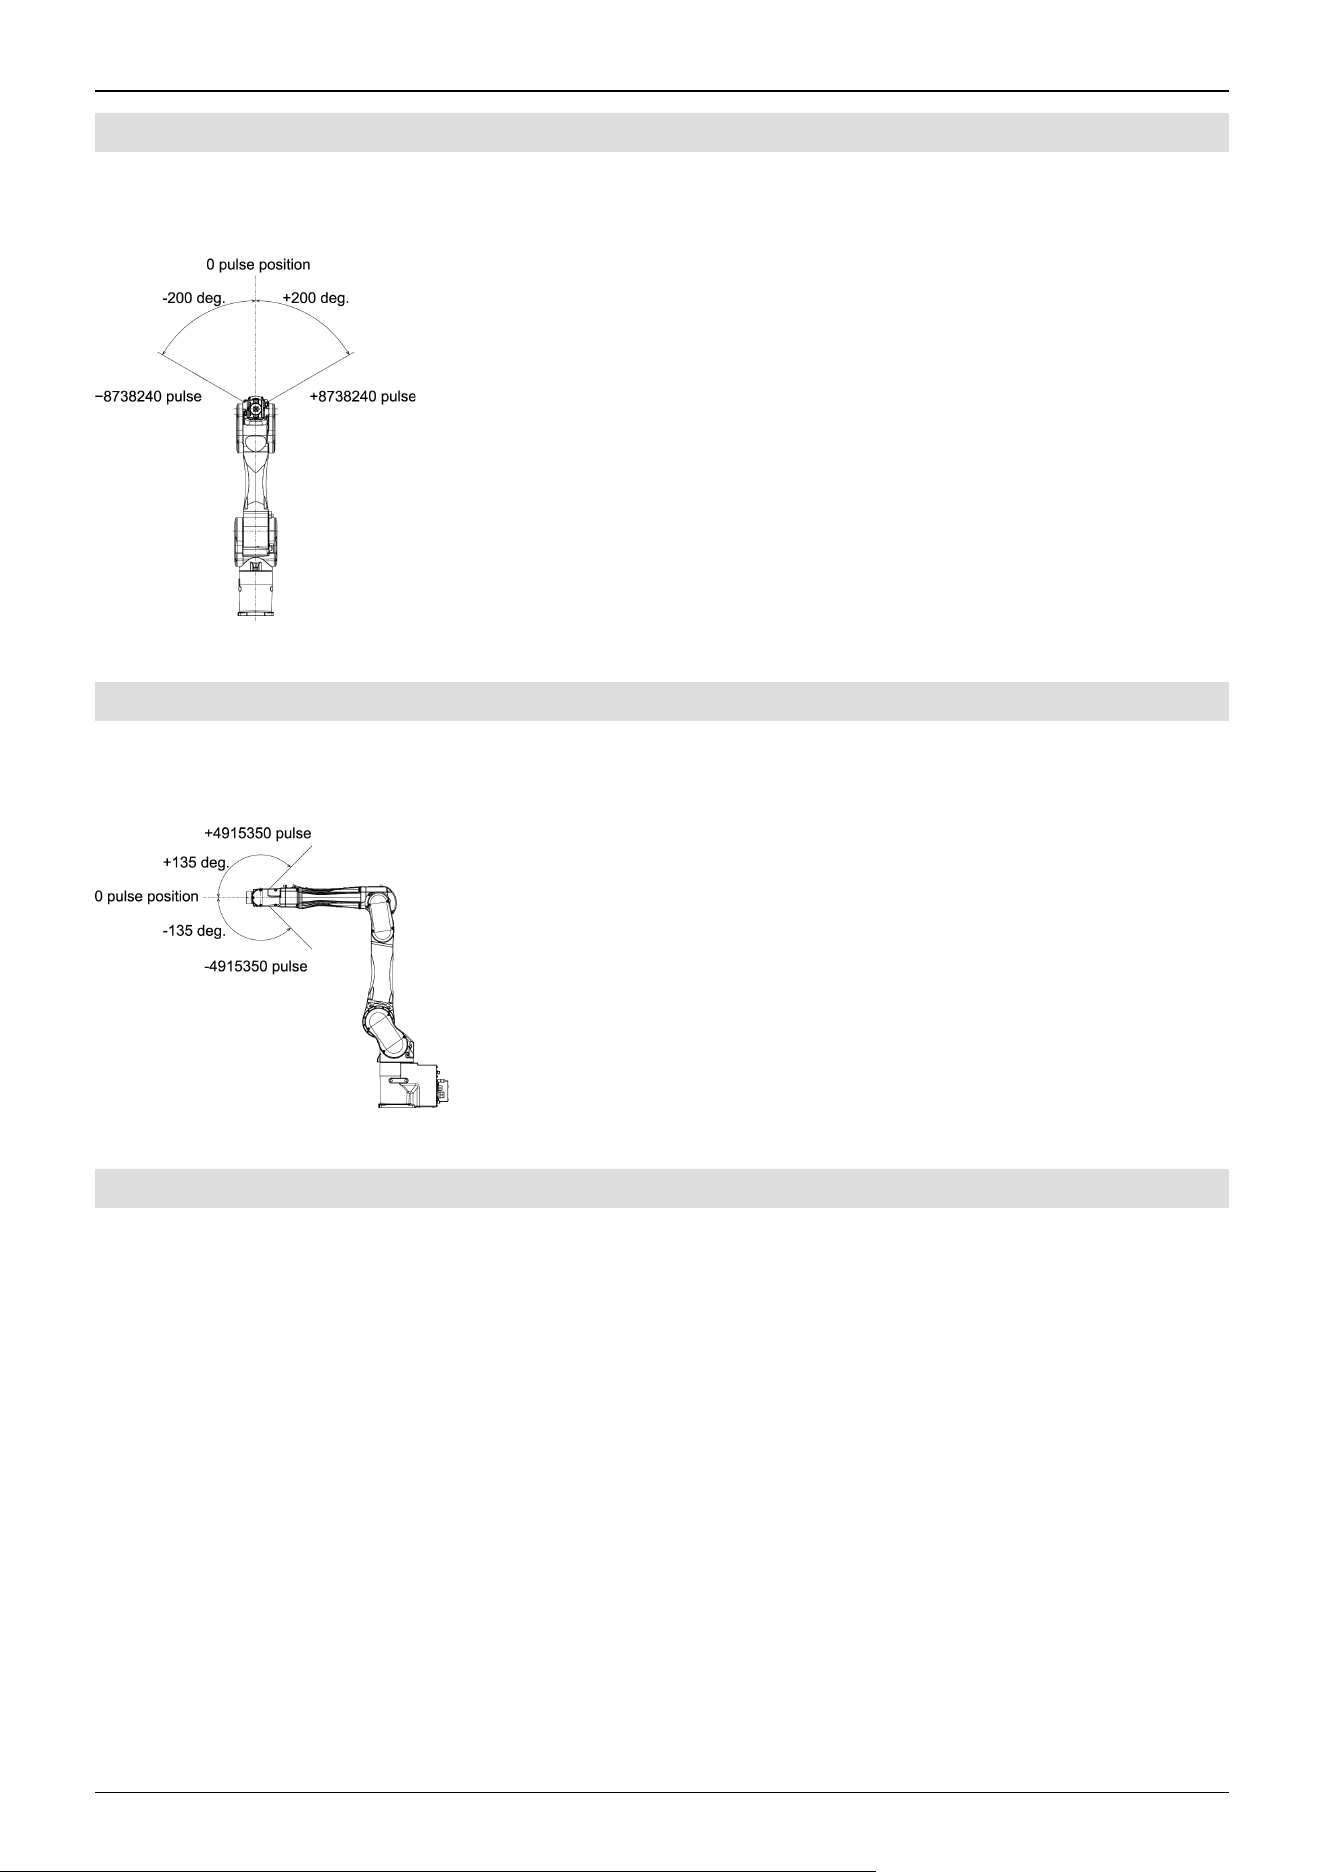
3.5.1.4 Joint #4 Maximum Pulse Range
From the angle of arm end, with the 0 pulse as a starting point, the clockwise pulse value is defined as positive (+), and the
counterclockwise pulse value is defined as negative (-).
3.5.1.5 Joint #5 Maximum Pulse Range
With the 0 pulse as a starting point, the clockwise pulse value is defined as positive (+), and the counterclockwise pulse value
is defined as negative (-).
3.5.1.6 Joint #6 Maximum Pulse Range
From the angle of arm end, with the 0 pulse as a starting point, the clockwise pulse value is defined as positive (+), and the
counterclockwise pulse value is defined as negative (-).
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
124
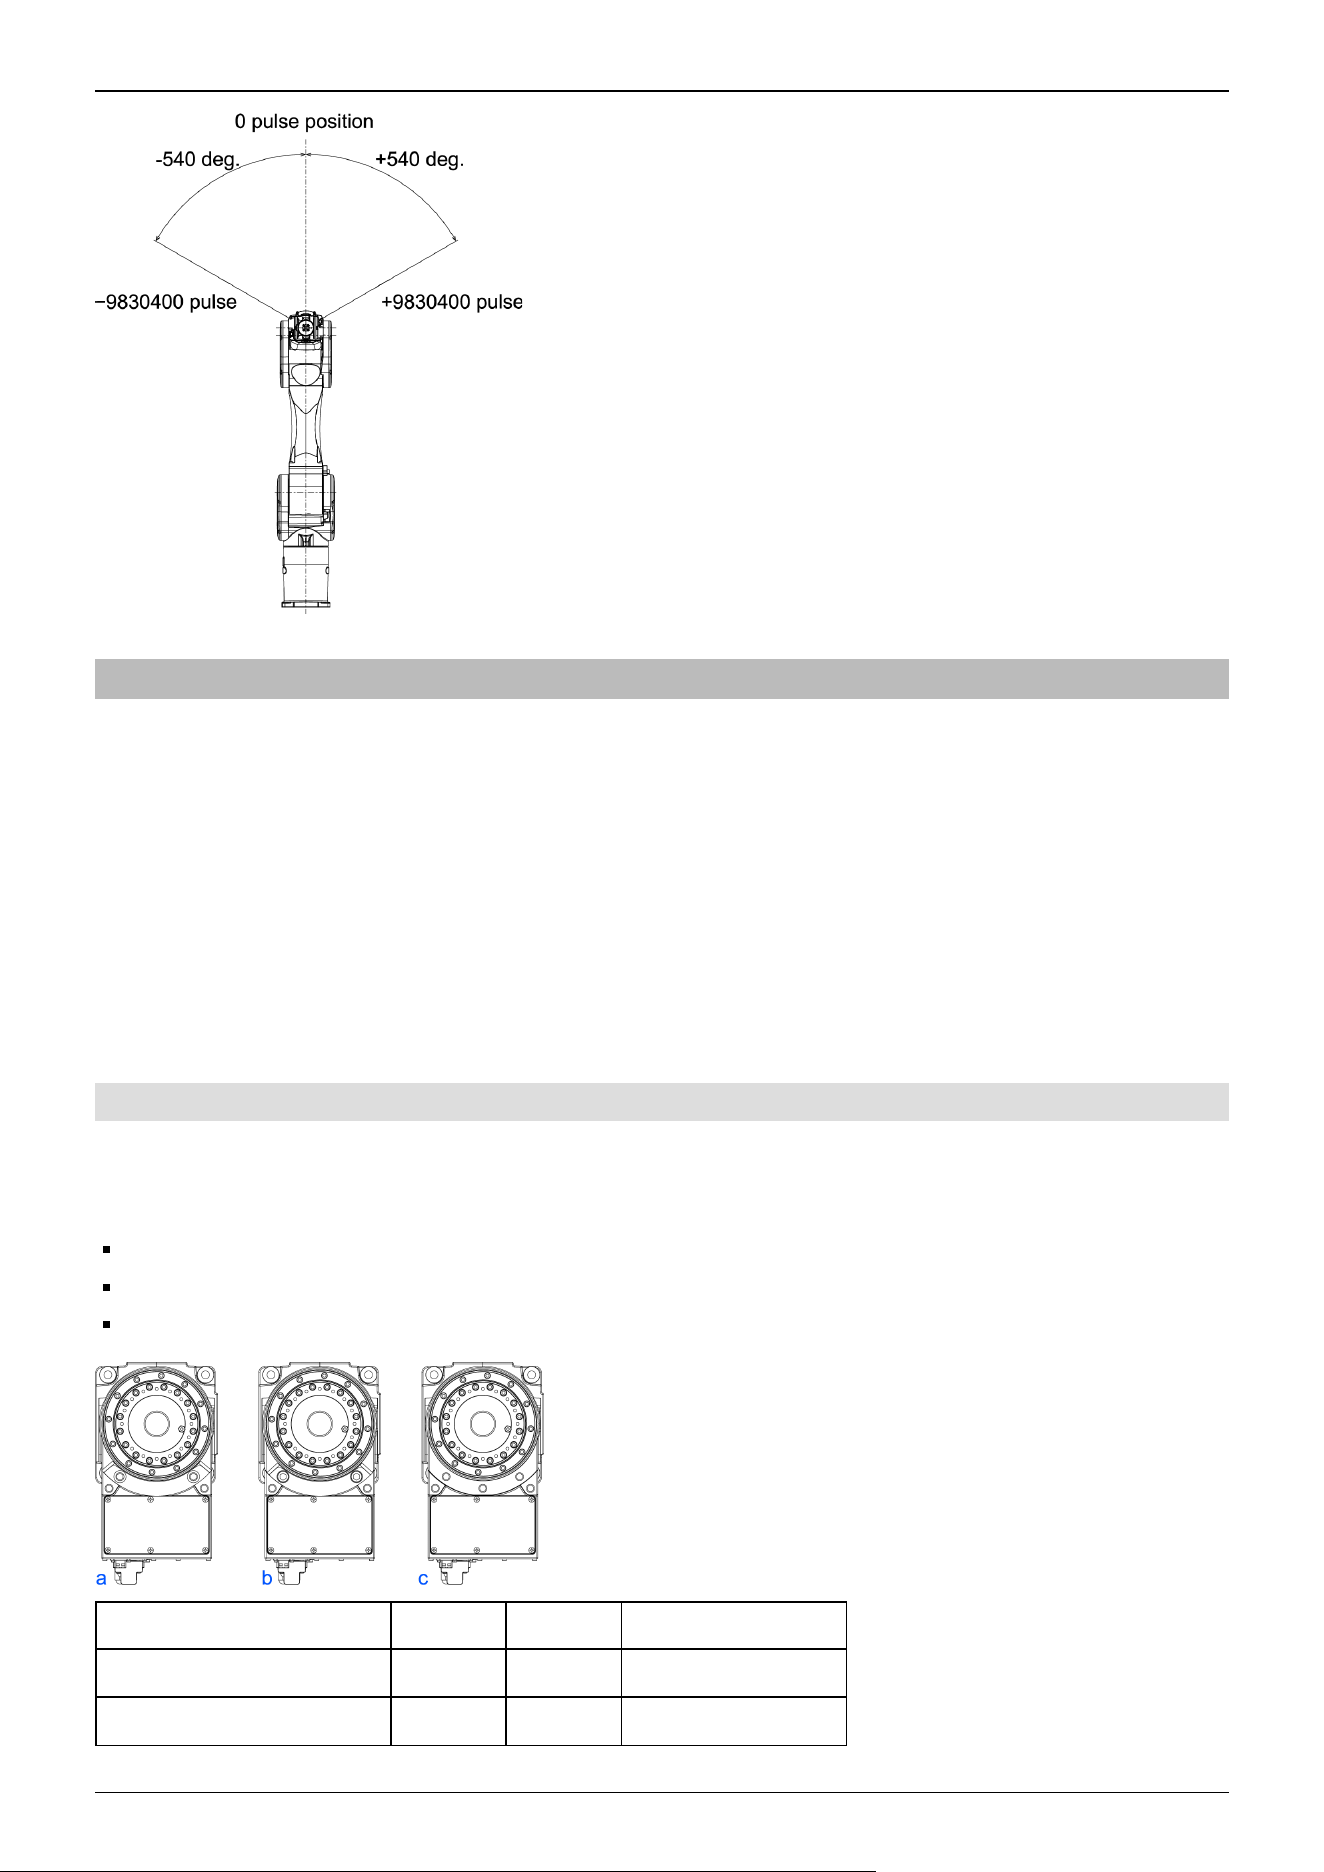
3.5.2 Setting the Work Envelope by Mechanical Stops
Using the variable mechanical stops physically limits the absolute area that the Manipulator can move.
Before starting any work, be sure to turn off the Manipulator.
Use bolts conforming to the specified length and surface processing (ex: nickel plating) with high corrosion resistance.
Specify the pulse range again after changing the position of the mechanical stop.
For details on the pulse range setting, refer to the following section.
Work Envelope Setting by Pulse Range (for Each Joint)
Be sure to set the pulse range inside the positions of the mechanical stop range.
3.5.2.1 Setting the Joint #1 Work Envelope
Install variable mechanical stop (J1) in the threaded holes corresponding to the angles to be set.
Normally a mechanical stop is not equipped.
Hexagon socket head cap bolt: M12×30×2 bolts
Strength: Compliant with ISO 898-1 property class: 10.9 or 12.9
Tightening torque: 42.0 ± 2.1 N·m (428 ± 21 kgf·cm)
a b c
Angle (°) ±110 ±105 ±240
Pulse ±7212700 ±6884840 ±15736800
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
125
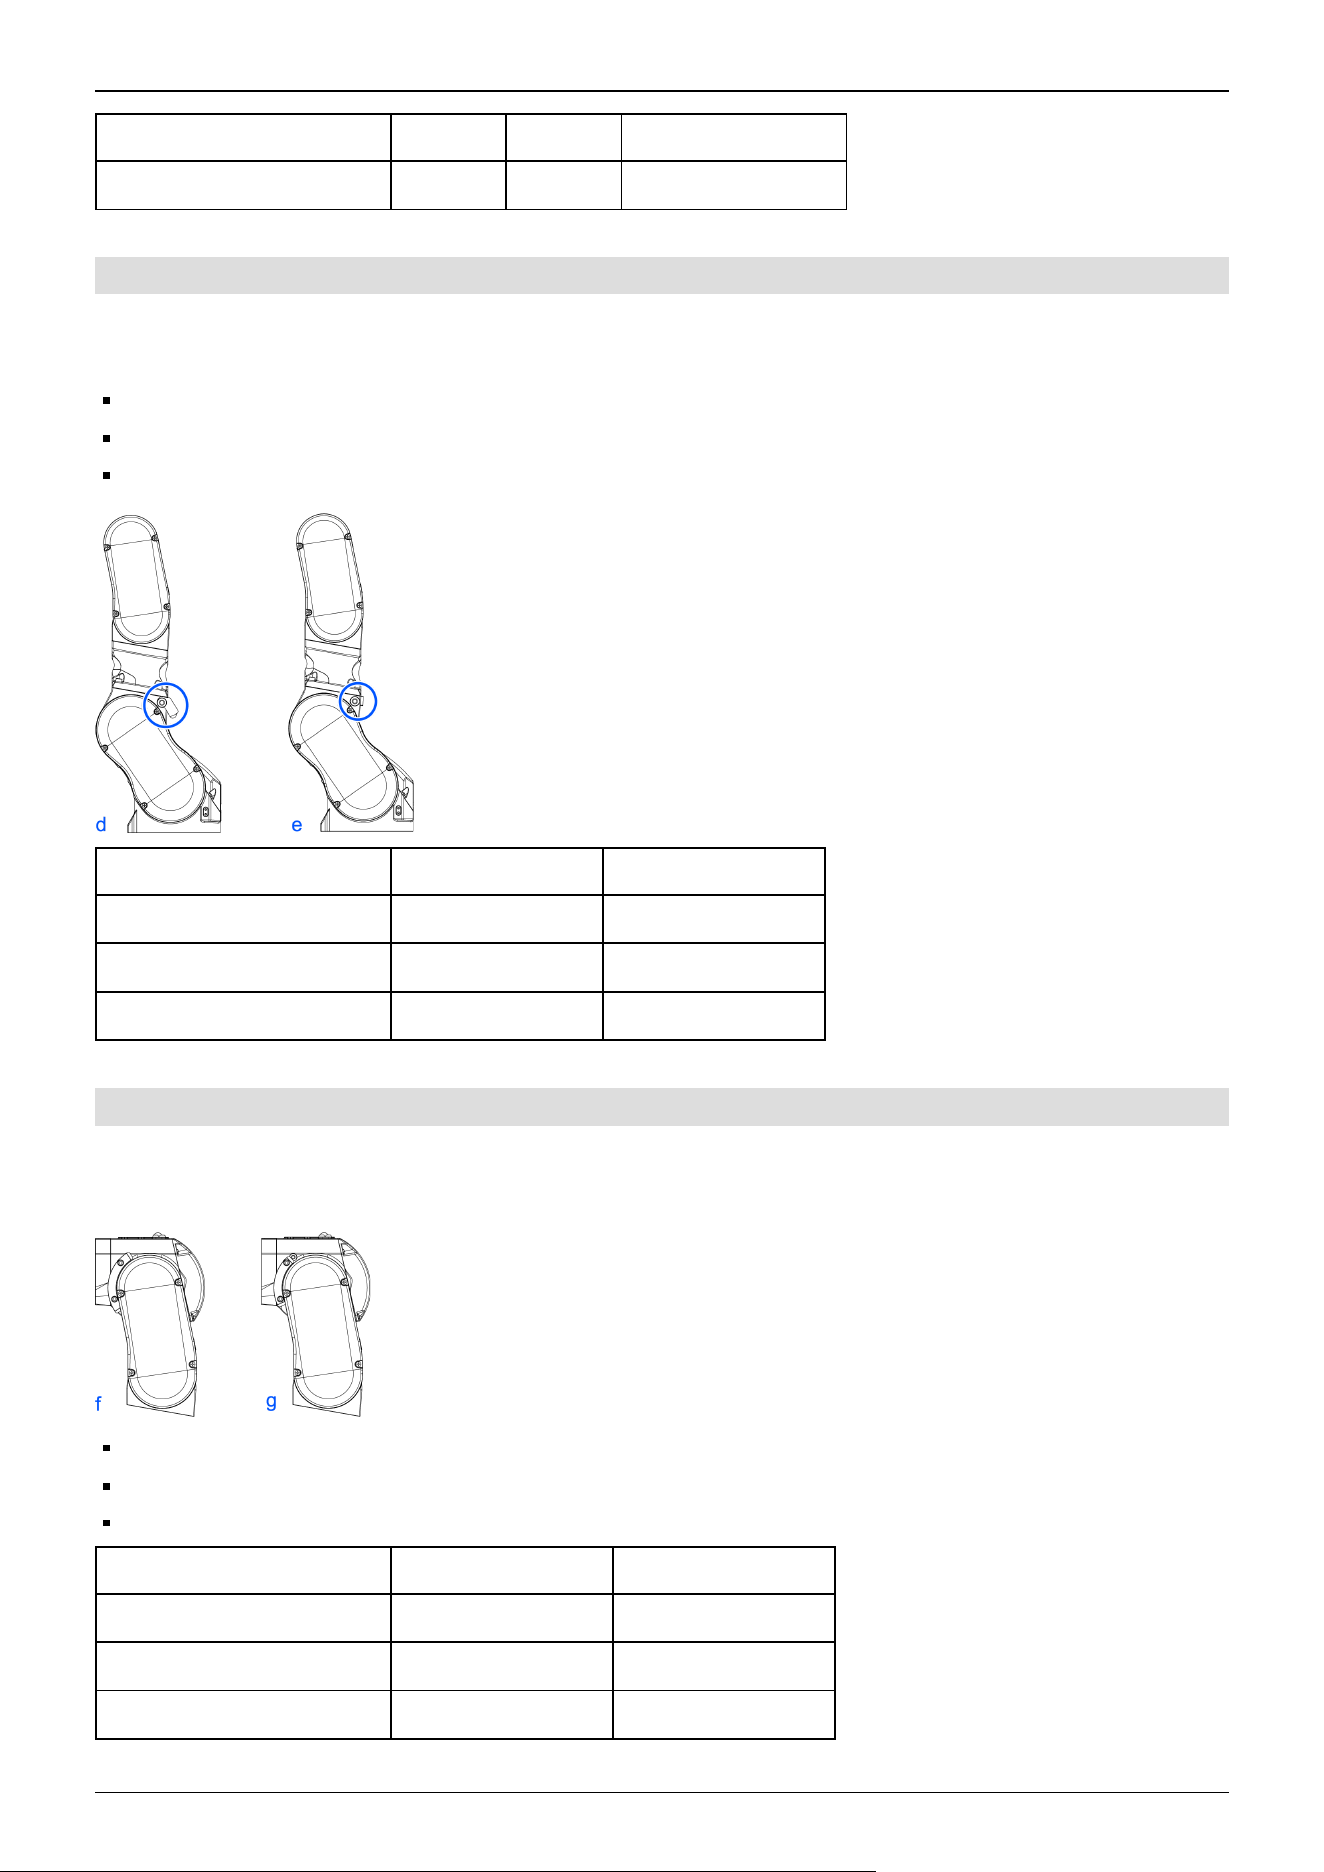
a b c
Variable Mechanical Stop (J1) Applied Applied Not applied (standard)
3.5.2.2 Setting the Joint #2 Work Envelope
Remove the mechanical stop installed as standard and install the variable mechanical stop (J2). (Joint #2 standard work
envelope -135 to +55°)
Hexagon socket head cap bolt: M10×35×2 bolts
Strength: Compliant with ISO 898-1 property class: 10.9 or 12.9
Tightening torque: 32.0 ± 1.6 N·m (326 ± 16 kgf·cm)
d e
Angle (°) -125, +45 -135, +55
Pulse -9830500, +3538980 -10616940, +4325420
Variable Mechanical Stop (J2) Applied Applied (standard)
3.5.2.3 Setting the Joint #3 Work Envelope
Remove the mechanical stop installed as standard and install the variable mechanical stop (J3). (Joint #3 standard work
envelope -61 to +202°)
Hexagon socket head cap bolt: M6×15×2 bolts
Strength: Compliant with ISO 898-1 property class: 10.9 or 12.9
Tightening torque: 13.0 ± 0.6 N·m (133 ± 6 kgf·cm)
f g
Angle (°) -51, +192 -61, +202
Pulse -3342336, +12582912 -3997696, +13238272
Variable Mechanical Stop (J3) Applied Applied (standard)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
126
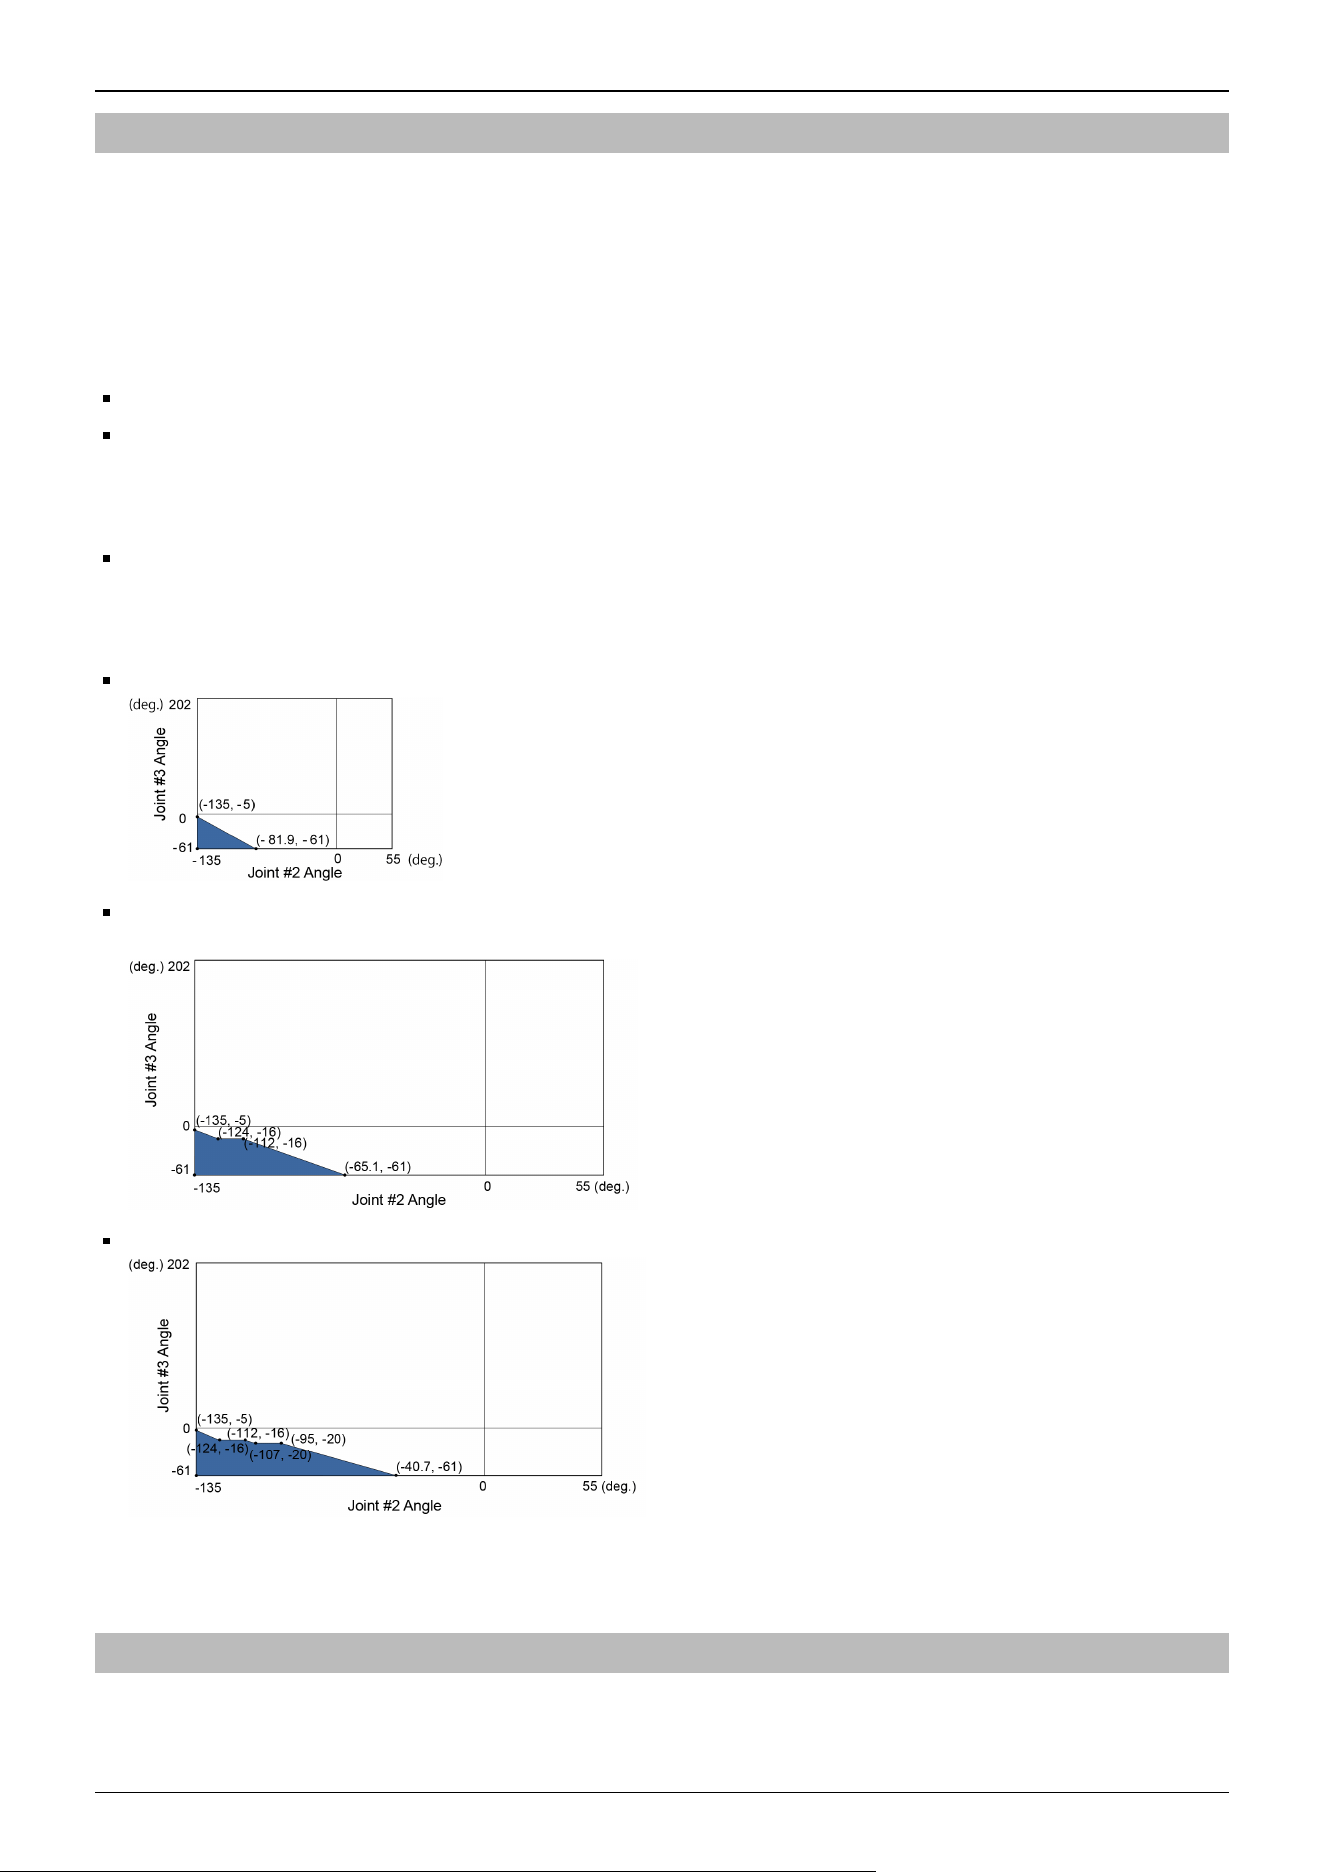
3.5.3 Restriction of Manipulator Operation by Joint Angle Combination
To prevent the arms of the Manipulator from interfering each other, the Manipulator operation is restricted in the specified
motion range according to the angle combination of the Joint #1, #2, and #3.
The Manipulator operation is restricted and the Manipulator stops when the joint angles are within the colored areas in the
following figure.
The restriction to Manipulator operation is enabled:
During CP motion command execution
When you attempt to execute the motion command for moving the Manipulator to a target point (or pose) in the specified
motion range.
The restriction to the Manipulator operation is disabled:
The Arms of the Manipulator momentarily go through the specified motion range during the PTP motion command
execution even though the joint angles of the Arms are in the colored areas of the figures above.
Combination of Joint #2 and #3
-110 deg. <= J1 <= 110 deg.
-140 deg. < J1<-110 deg. or 110 deg. < J1< 140 deg.
-240 deg. < J1<-220 deg. or 220 deg. < J1< 240 deg.
-220 deg. <= J1<=-140 deg. or 140 deg. < J1< 220 deg.
(deg.=°)
3.5.4 Coordinate System
The origin point is where the Manipulator’s installation face intersects with the rotation axis of Joint #1.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
127
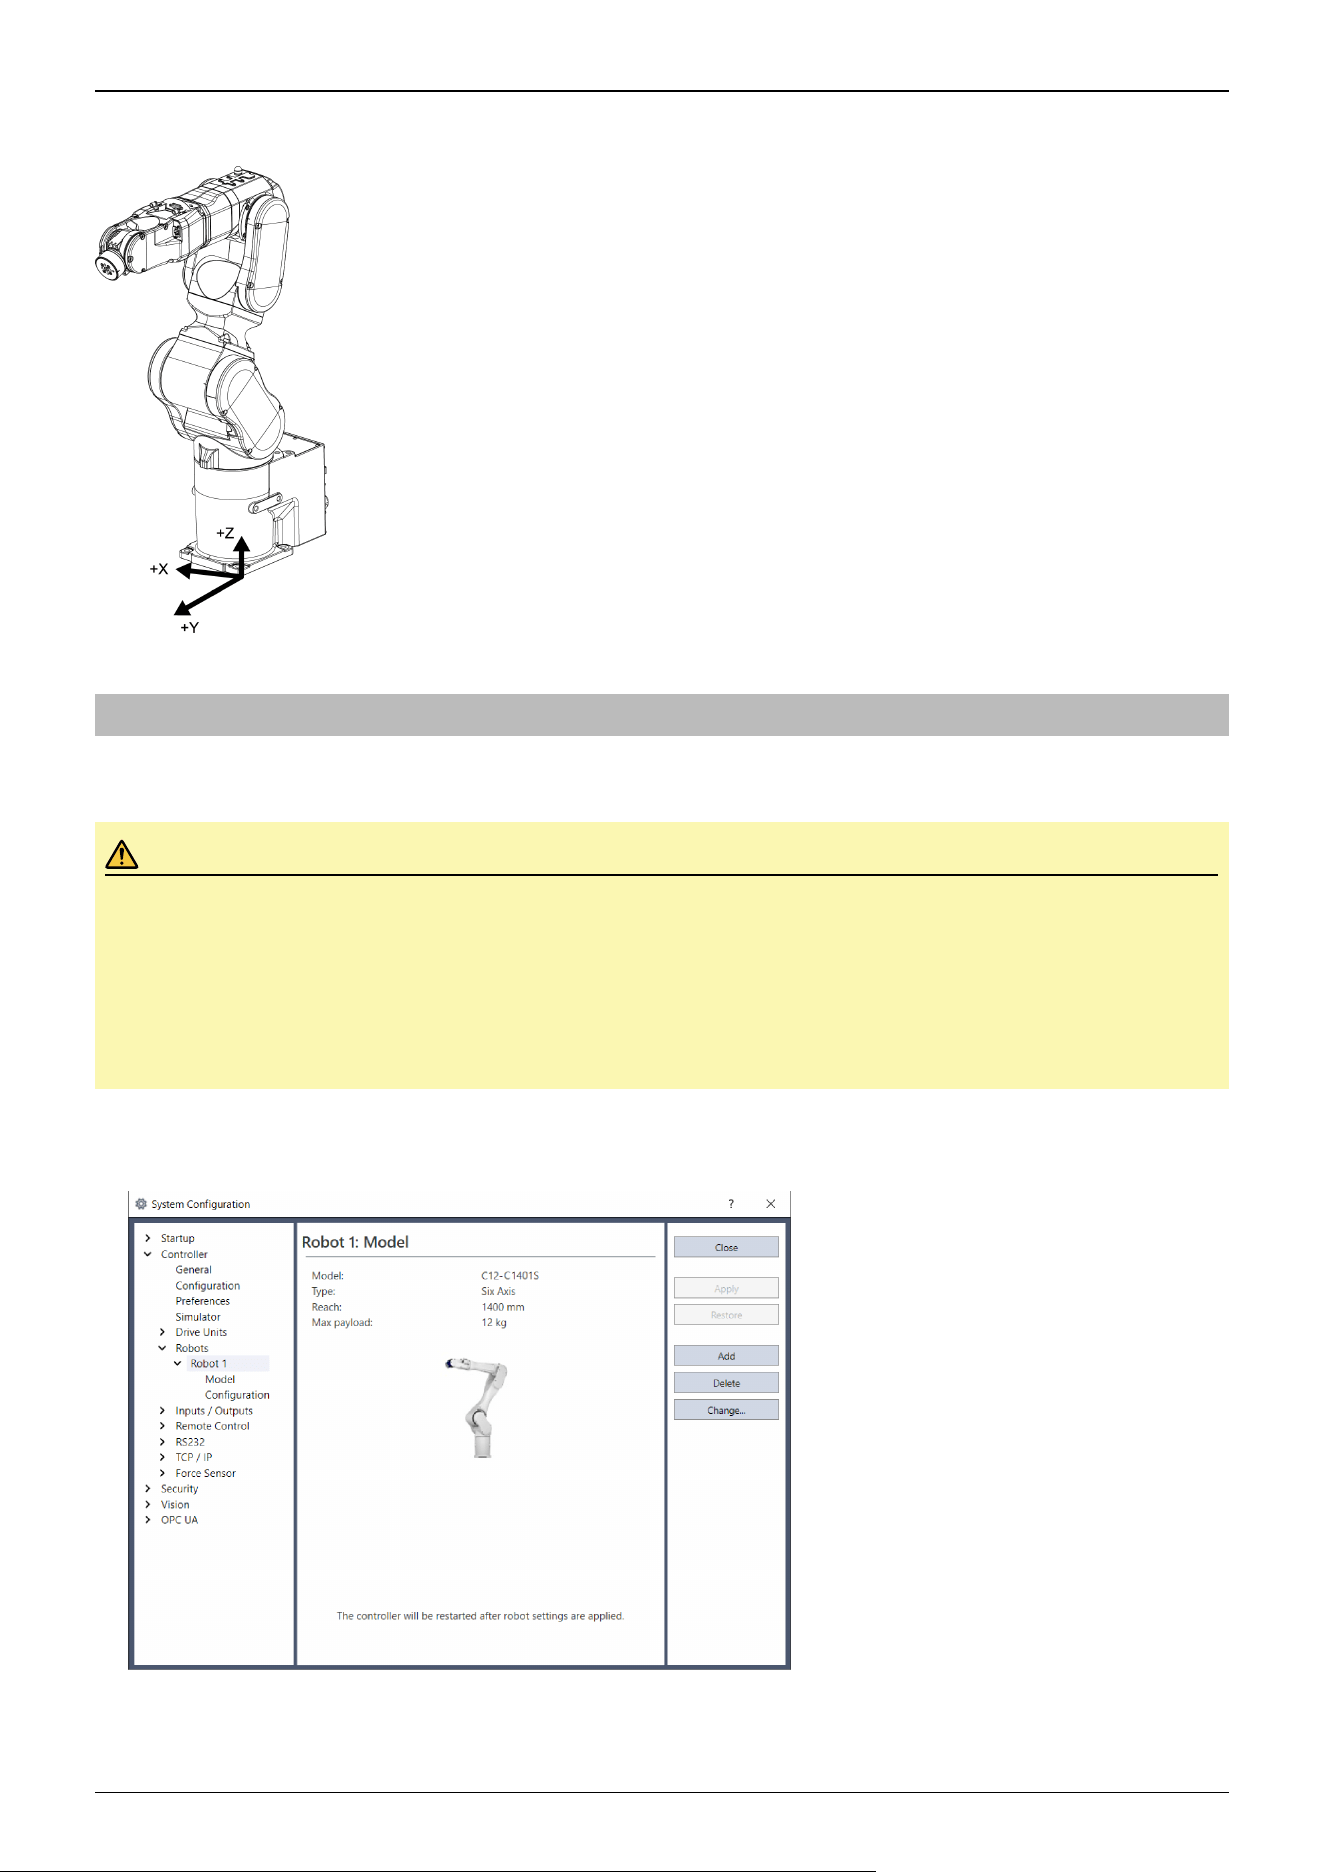
For details on the coordinate system, refer to the Epson RC+ Users Guide manual.
3.5.5 Changing the Robot
This section describes how to change the Manipulator model on Epson RC+.
CAUTION
Changing the Manipulator should be done with great caution. It initializes the robot calibration parameters (Hofs,
CalPls), additional axis information, and PG parameter data. Before changing the robot, make sure to save the
calibration data by following the procedure below.
1. Select the Epson RC+ menu-[Setup]-[System Configuration].
2. Select [Controller]-[Robots]-[Robot**]-[Calibration] from the tree list. Then, click [Save].
1. Select the Epson RC+ menu-[Setup]-[System Configuration].
2. Select [Controller]-[Robots]-[Robot**] from the tree list. (Dialog image: Epson RC+ 8.0)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
128
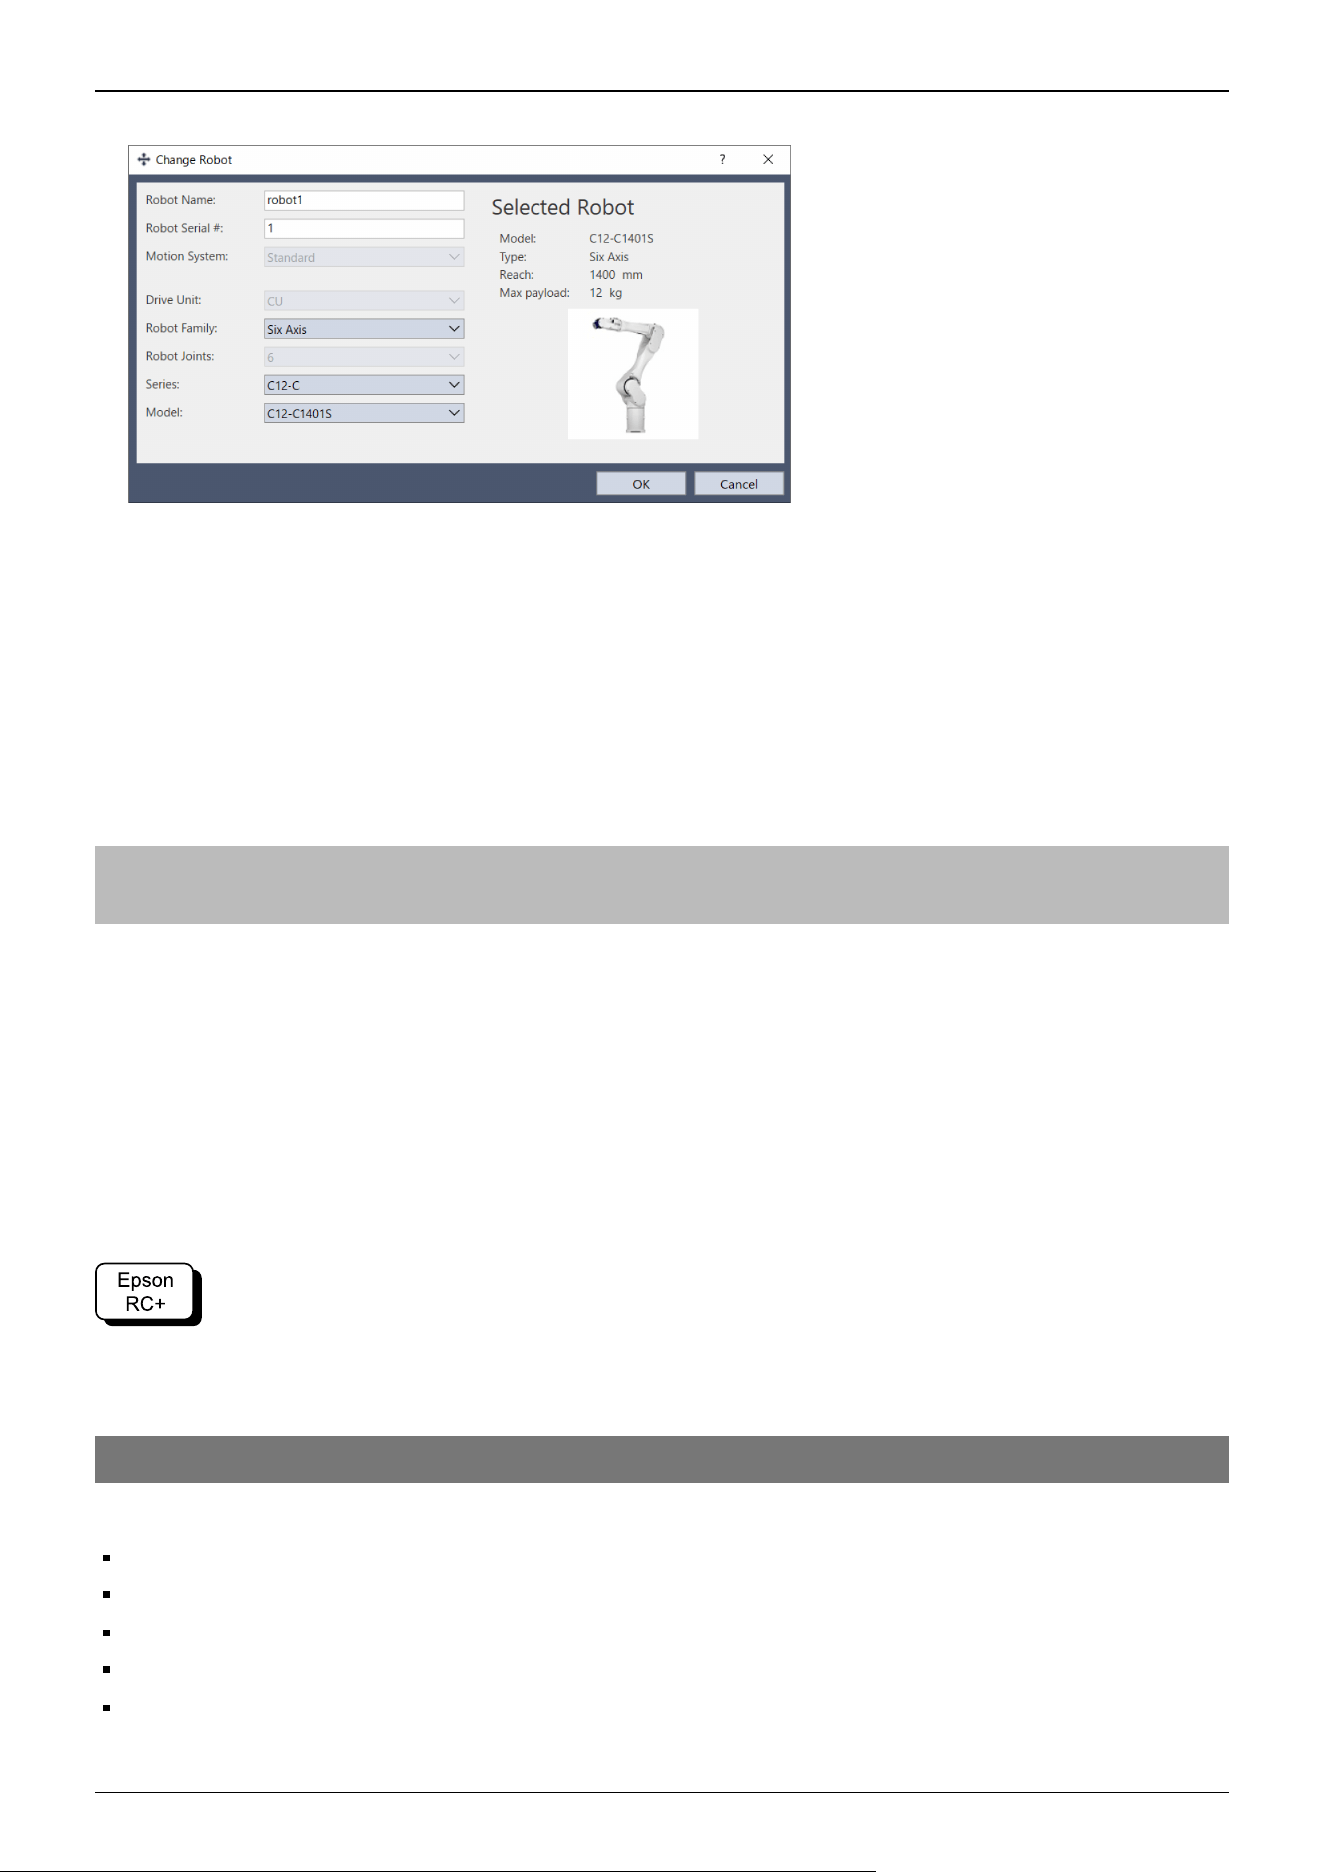
3. Click the [Change] button. The following dialog box will be displayed.
4. Input the robot name and serial number printed on the name plate of the Manipulator. Any serial number can be entered.
However, enter the number printed on the Manipulator.
5. Select the robot type in the [Robot type] box.
6. Select the series name of the Manipulator in the [Series] box.
7. Select the robot model in the [Model] box.
Available robots will be displayed according to the format of the currently installed motor driver. When [Dry run] is used,
all the Manipulators of the series selected in Step 6 will be displayed.
8. Click the [OK] button. The Controller is restarted.
3.5.6 Setting the Rectangular Range in the XY Coordinate System of the
Manipulator
The Cartesian (rectangular) range in the XY coordinate system of the Manipulator is specified by the limited Manipulator
operation area and the XYLIM setting. The limited Manipulator operation area is defined so that the hand does not interfere
with the rear side of the Manipulator. The XYLIM setting that you can determines the upper and lower limits of the X and Y
coordinates.
These settings are software-based limit, and so it does not change the maximum physical range. The maximum physical range
is based on the position of the mechanical stops.
These settings are disabled during a joint jogging operation. Therefore, be careful not to allow the hand to collide with the
Manipulator or peripheral equipment.
Go to [Tools] - [Robot Manager] - [XYZ Limits] panel, and make the setting. This can also be set using the XYLim statement
in [Command Window].
3.6 Options
C12 series Manipulator has the following options.
Brake Release Unit
Camera Plate Unit
Tool Adapter (ISO flange)
Variable Mechanical Stop
User Wires and Pneumatic Tubes
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
129
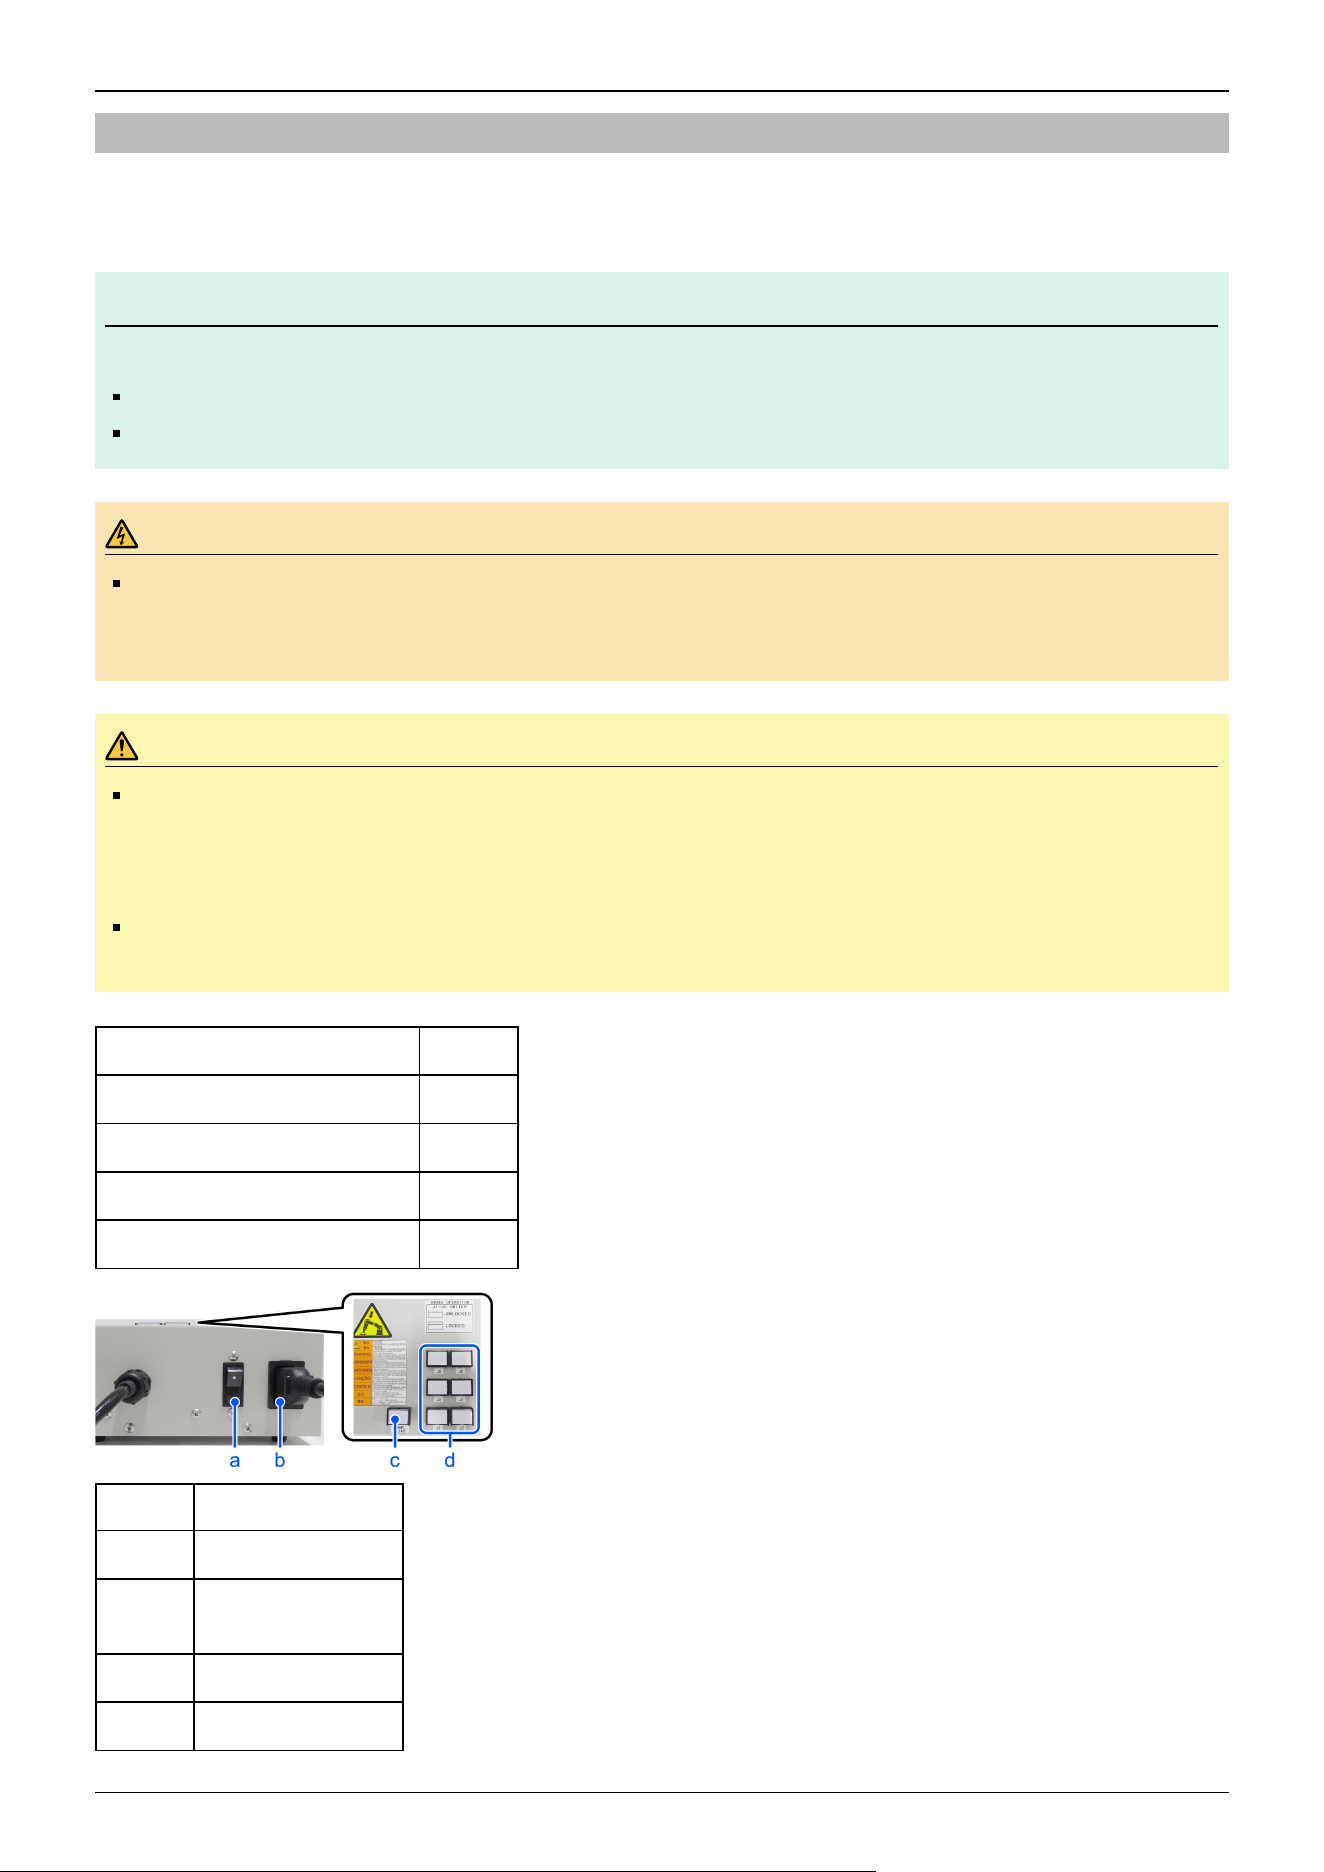
3.6.1 Brake Release Unit
While the electromagnetic brake is on (such as in emergency mode), you cannot move any arm by pushing manually. You can
move the Arms by hand using the brake release unit while the Controller power is off or right after unpacking.
KEY POINTS
Precautions regarding the brake release unit
Be sure to prepare at least one set of the brake release unit.
Place at easy-to-reach location so that you can use it immediately when in a emergency situation.
WARNING
Turn off the power to the Robot Controller and brake release unit when connecting or replacing the brake
release unit or external short connector. Inserting or removing connectors with the power on may result in
electric shock and/or malfunction of the robot system.
CAUTION
Normally, release the brakes of joints one at a time. If the brakes of two or more joints must be released
simultaneously due to unavoidable reasons, use extreme care. Releasing the brakes of multiple joints
simultaneously may cause the arm to fall in an unexpected direction, resulting in hands or fingers getting
caught or damage or failure of the Manipulator.
After releasing the brake, the arm may fall by its own weight or move to the unexpected direction. Make sure
to prepare a countermeasure to prevent the arm from falling and check the operation environment is safe.
Width 180 mm
Depth 150 mm
Height 87 mm
Weight (Cables are not included.) 1.7 kg
Cable to the Manipulator 2 m
Symbol Description
a Power switch
b
Power Cable
(You must provide.)
c Power lamp
d Brake release switch
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
130
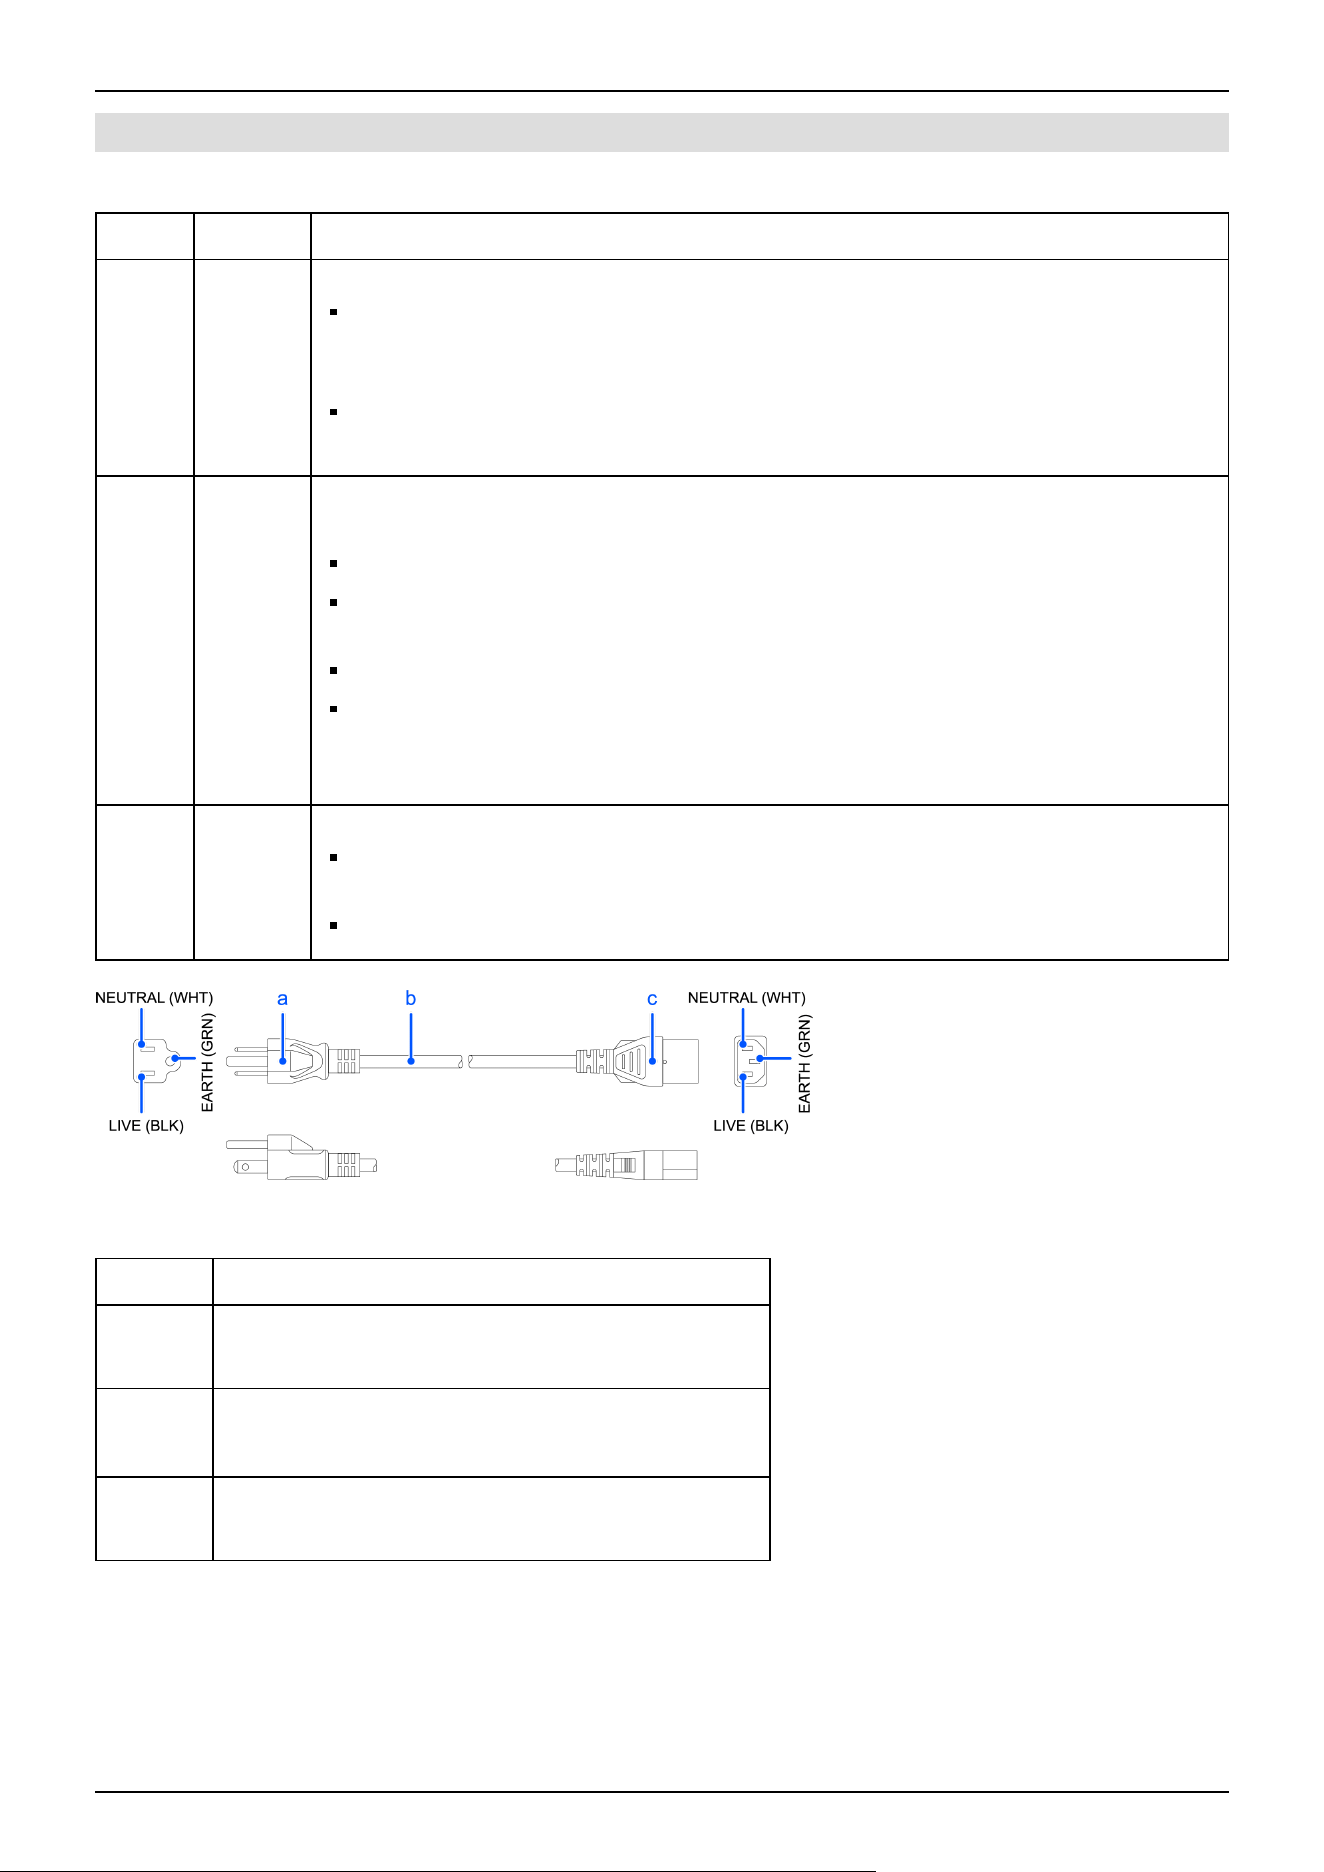
3.6.1.1 Power Cable
You must provide a power cable. Be sure to use the specifications below.
Symbol Item Specifications
a Plug
Comply with local safety regulation
Class I (2P + PE), AC250 V, 6 A or 10 A
Ex.: CEE Pub.7 Certified, CCC Certified, KC Certified, BS1363 Certified, PSB Certified, BIS
Certified, SABS Certified
Class I (2P + PE), AC125 V, 7 A, 12 A, or 15 A etc.
Ex.: UL Certified, PSE Certified, BSMI Certified
b
Flexible
cable
Comply with IEC/EN standards or local safety regulation
Example:
IEC 60227-1: General requirements
IEC 60227-5: Polyvinyl chloride insulated cables of rated voltages up to and including 450/750
V - Part 5: Flexible cables (cords)
EN 50525-1: General requirements
EN 50525-2-11: Electric cables - Low voltage energy cables of rated voltages up to and
including 450/750 V (Uo/U) - Part 2-11: Cables for general applications - Flexible cables with
thermoplastic PVC insulation
c
Appliance
coupler
Comply with IEC/EN standards or local safety regulation
IEC / EN 60320-1: Appliance couplers for household and similar general purposes - Part 1:
General requirements
Standard Sheet C13: AC250 V/10 A
For Japan
Item Specifications
Plug
PSE Certified
Class I (2P+PE), AC125 V, 7 A or higher
Code
PSE Certified
0.75 mm
2
or more
Connector
PSE Certified
IEC 60320-1 Standard Sheet C13: AC125 V/10 A or higher
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
131
Precautions for use
CAUTION
Operating the Manipulator without a brake release unit or external short connector connected may cause the
brake to fail to release, possibly damaging the brake.
After using the brake release unit, be sure to connect the external short circuit connector to the Manipulator or
make sure to leave the connector for the brake release unit connected.
Keep the external short connector. Otherwise you cannot release the brakes.
If you turn on the brake release unit while the brake release switch is being pressed, an unintended arm may
move downward. Before turning on the brake release unit, make sure that the brake release switch is not
pressed.
If you turn on the brake release unit without the connector, it may lead to the short for the male pin used in the
connector. Before turning on the brake release unit, make sure that the connector is connected.
3.6.1.2 Installing the Brake Release Unit
1. Turn off the Controller.
2. If the M/C power cable is not connected to the Controller:
Connect the M/C short connector, or connect the Controller.
(Keep the Controller power off.)
If the M/C power cable is already connected to the Controller:
Go to the step (3).
3. Remove the external short connector.
4. Connect the brake release unit to the connector of the connection cable.
3.6.1.3 Removing the Brake Release Unit
1. Turn off the brake release unit.
2. Remove the power cable of the brake release unit.
3. Disconnect the brake release unit from the connector of the connection cable.
4. If the M/C short connector is connected to the M/C power cable, remove the short connector.
5. Connect the external short connector to the connector of the connection cable.
3.6.1.4 How to Use the Brake Release Unit
CAUTION
After releasing the brake, the arm may fall by its own weight or move to the unexpected direction. Make sure
to prepare a countermeasure to prevent the arm from falling and check the operation environment is safe.
If the arm you released its brake moves awkwardly or faster than usual, stop the operation promptly and
contact the supplier. The brake release unit may be broken. If you keep operating the Manipulator, it may lead
to the breakdown of the Manipulator or you may get your hand or fingers caught.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
132
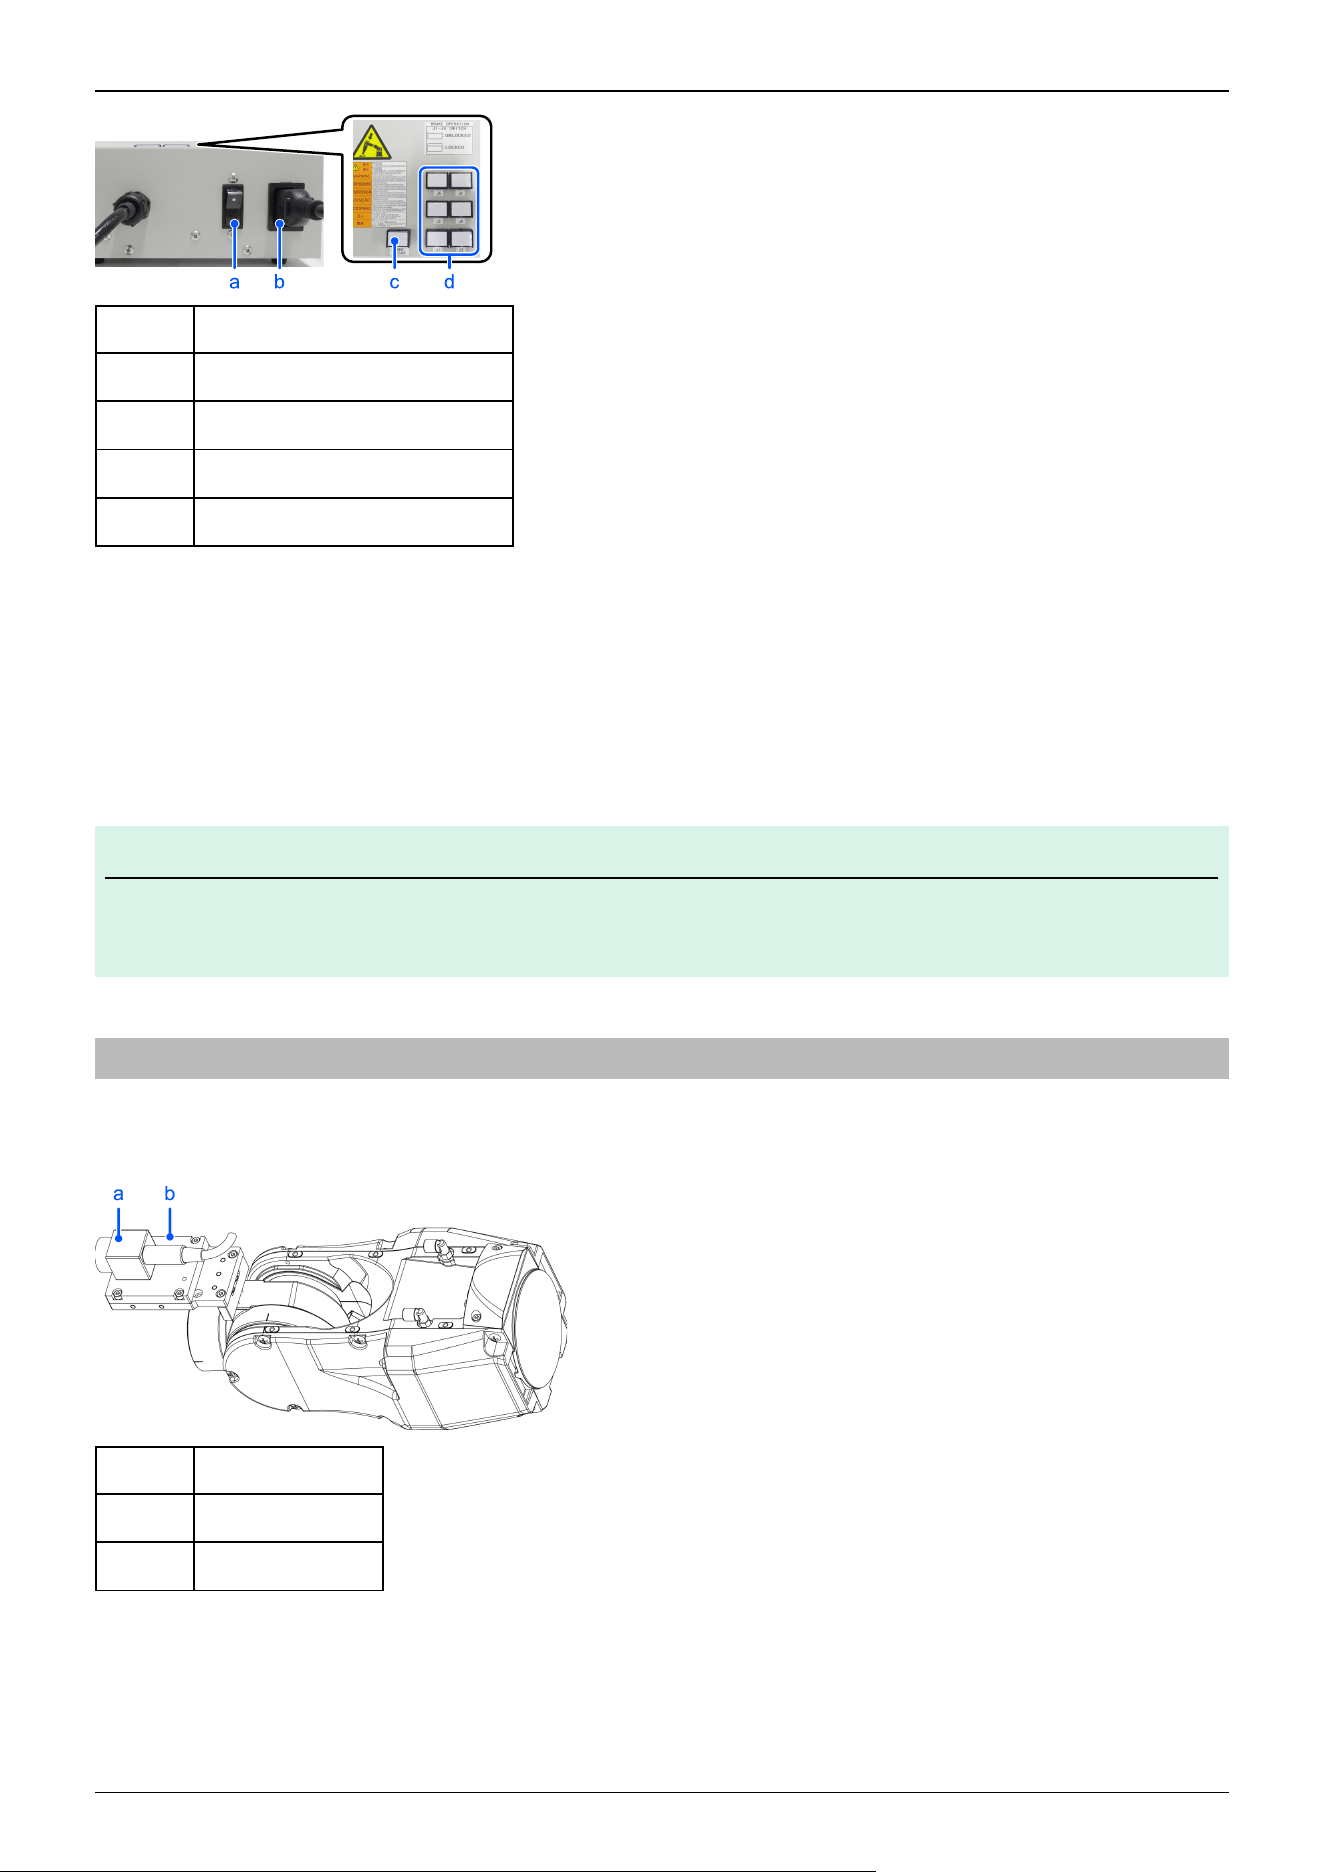
Symbol Description
a Power switch
b Power cable (You must provide.)
c Power lamp
d Brake release switch
1. Refer to “Installing the Brake Release Unit” above to connect the brake release unit to the connector of the connection
cable.
2. Plug the power cable into the brake release unit.
3. Plug the power cable into the power supply plug.
4. Turn on the brake release unit. When the brake release unit is enabled, the power lamp lights up.
5. Press the switch of the arm (J1 to J6) you want to move and then move the arm. Press the switch again. The brake will be
released. The brake will be enabled by pressing the switch once again.
KEY POINTS
Move the arm the brake is released by two persons or more (one presses the switch and one moves the arm).
The arm can be very heavy and needs the significant force to move.
3.6.2 Camera Plate Unit
To mount a camera to the C12 series Manipulator, you need to mount the camera plate unit first.
Appearance of arm end with camera
Symbol Description
a Camera
b Camera Plate Unit
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
133
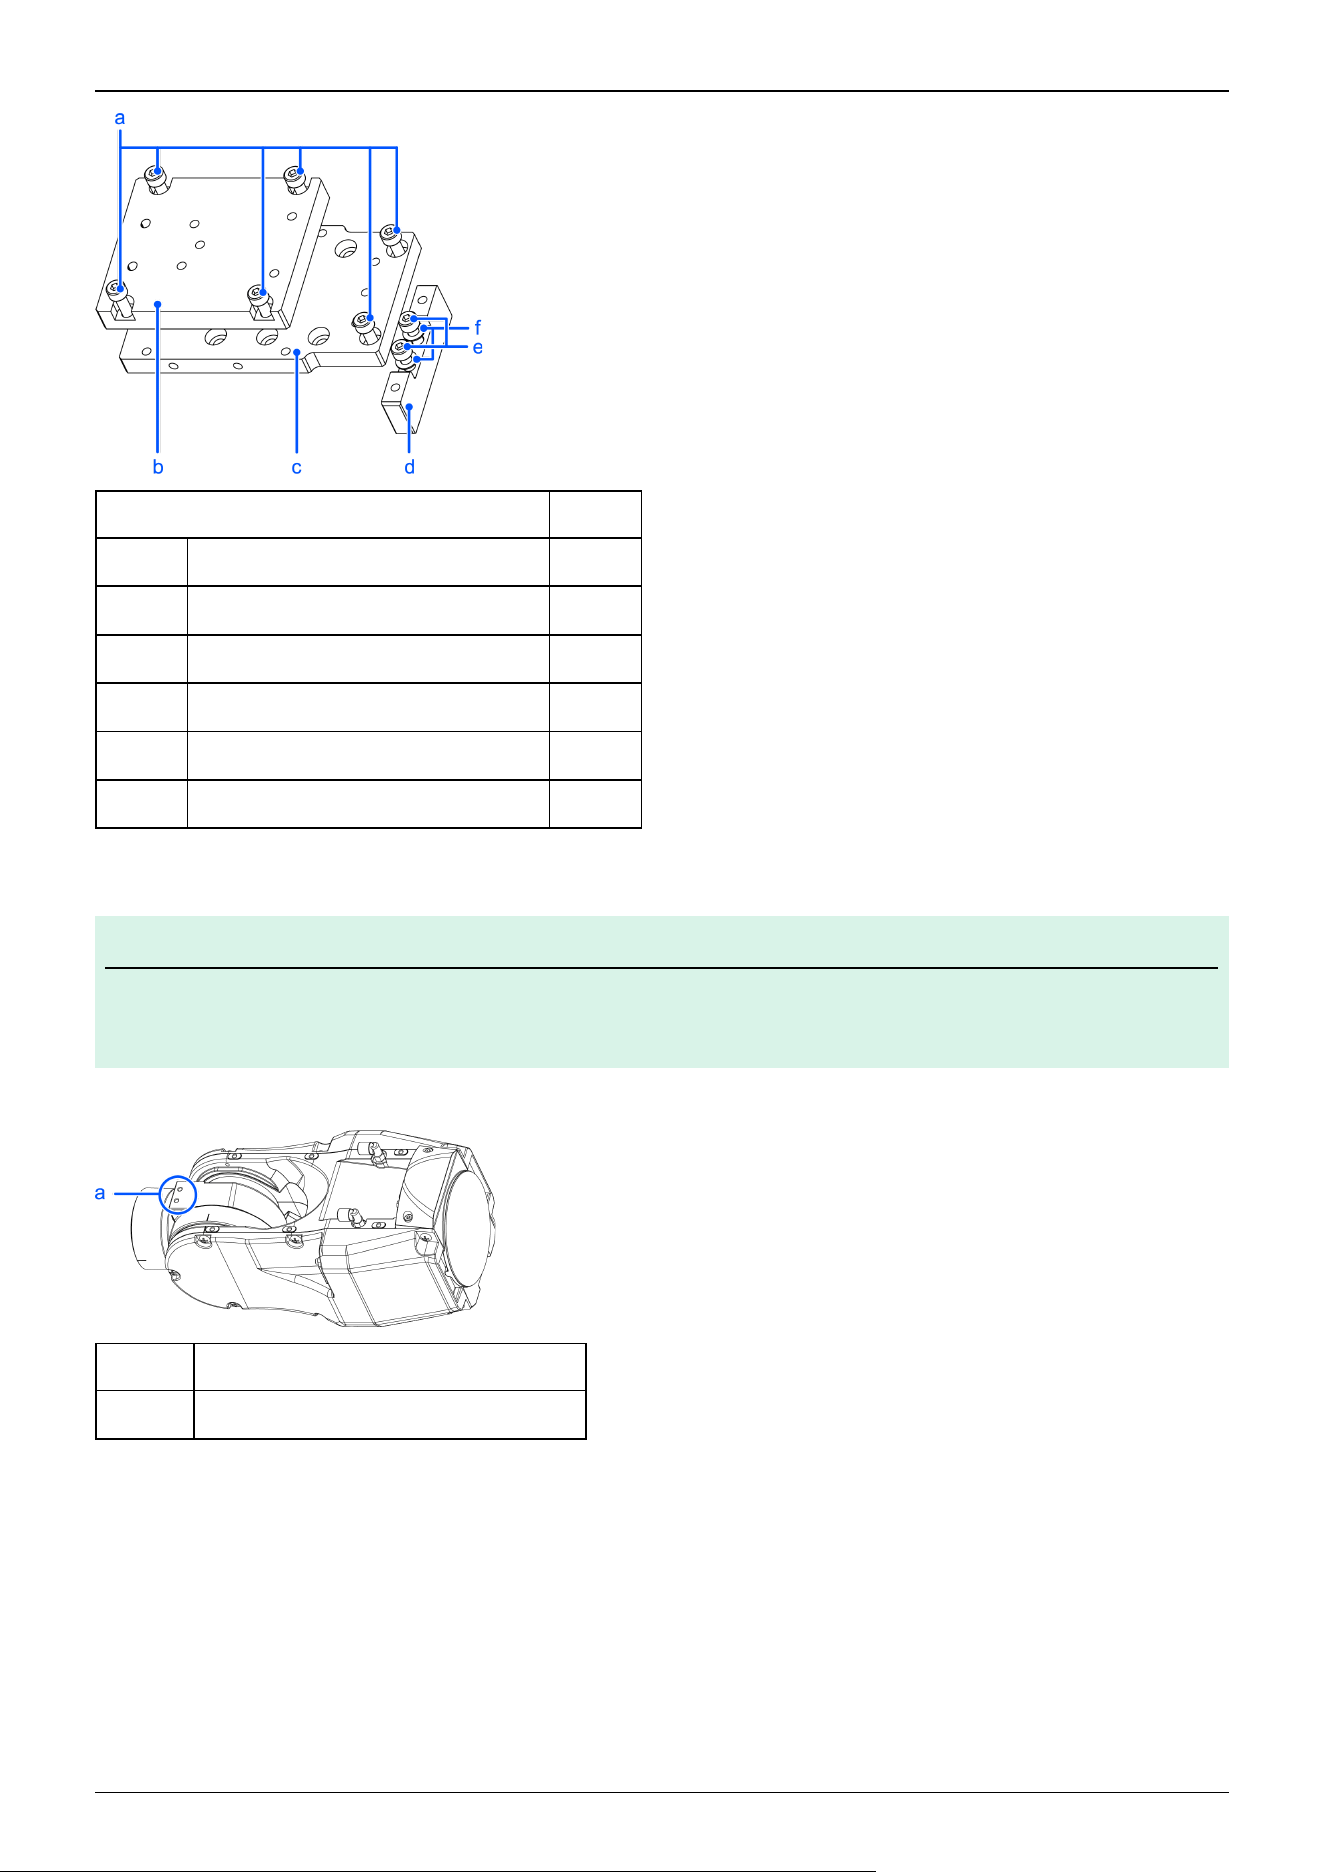
Parts Included Qty.
a Hexagon socket head cap bolt M4×12 6
b Camera adapter plate 1
c Camera mid plate 1
d Camera base plate 1
e Hexagon socket head cap bolt M4×20 2
f Plain washer for M4 (small washer) 2
Installation
KEY POINTS
For details of tightening the hexagon socket head cap bolt, refer to the following section.
Tightening the Hexagon Socket Head Cap Bolts
Mounting holes for the camera base plate on the C12 series Manipulator
Symbol Description
a Mounting holes for the camera base plate
For installation procedure, refer to the following manual.
"Epson RC+ Option Vision Guide Hardware & Setup"
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
134
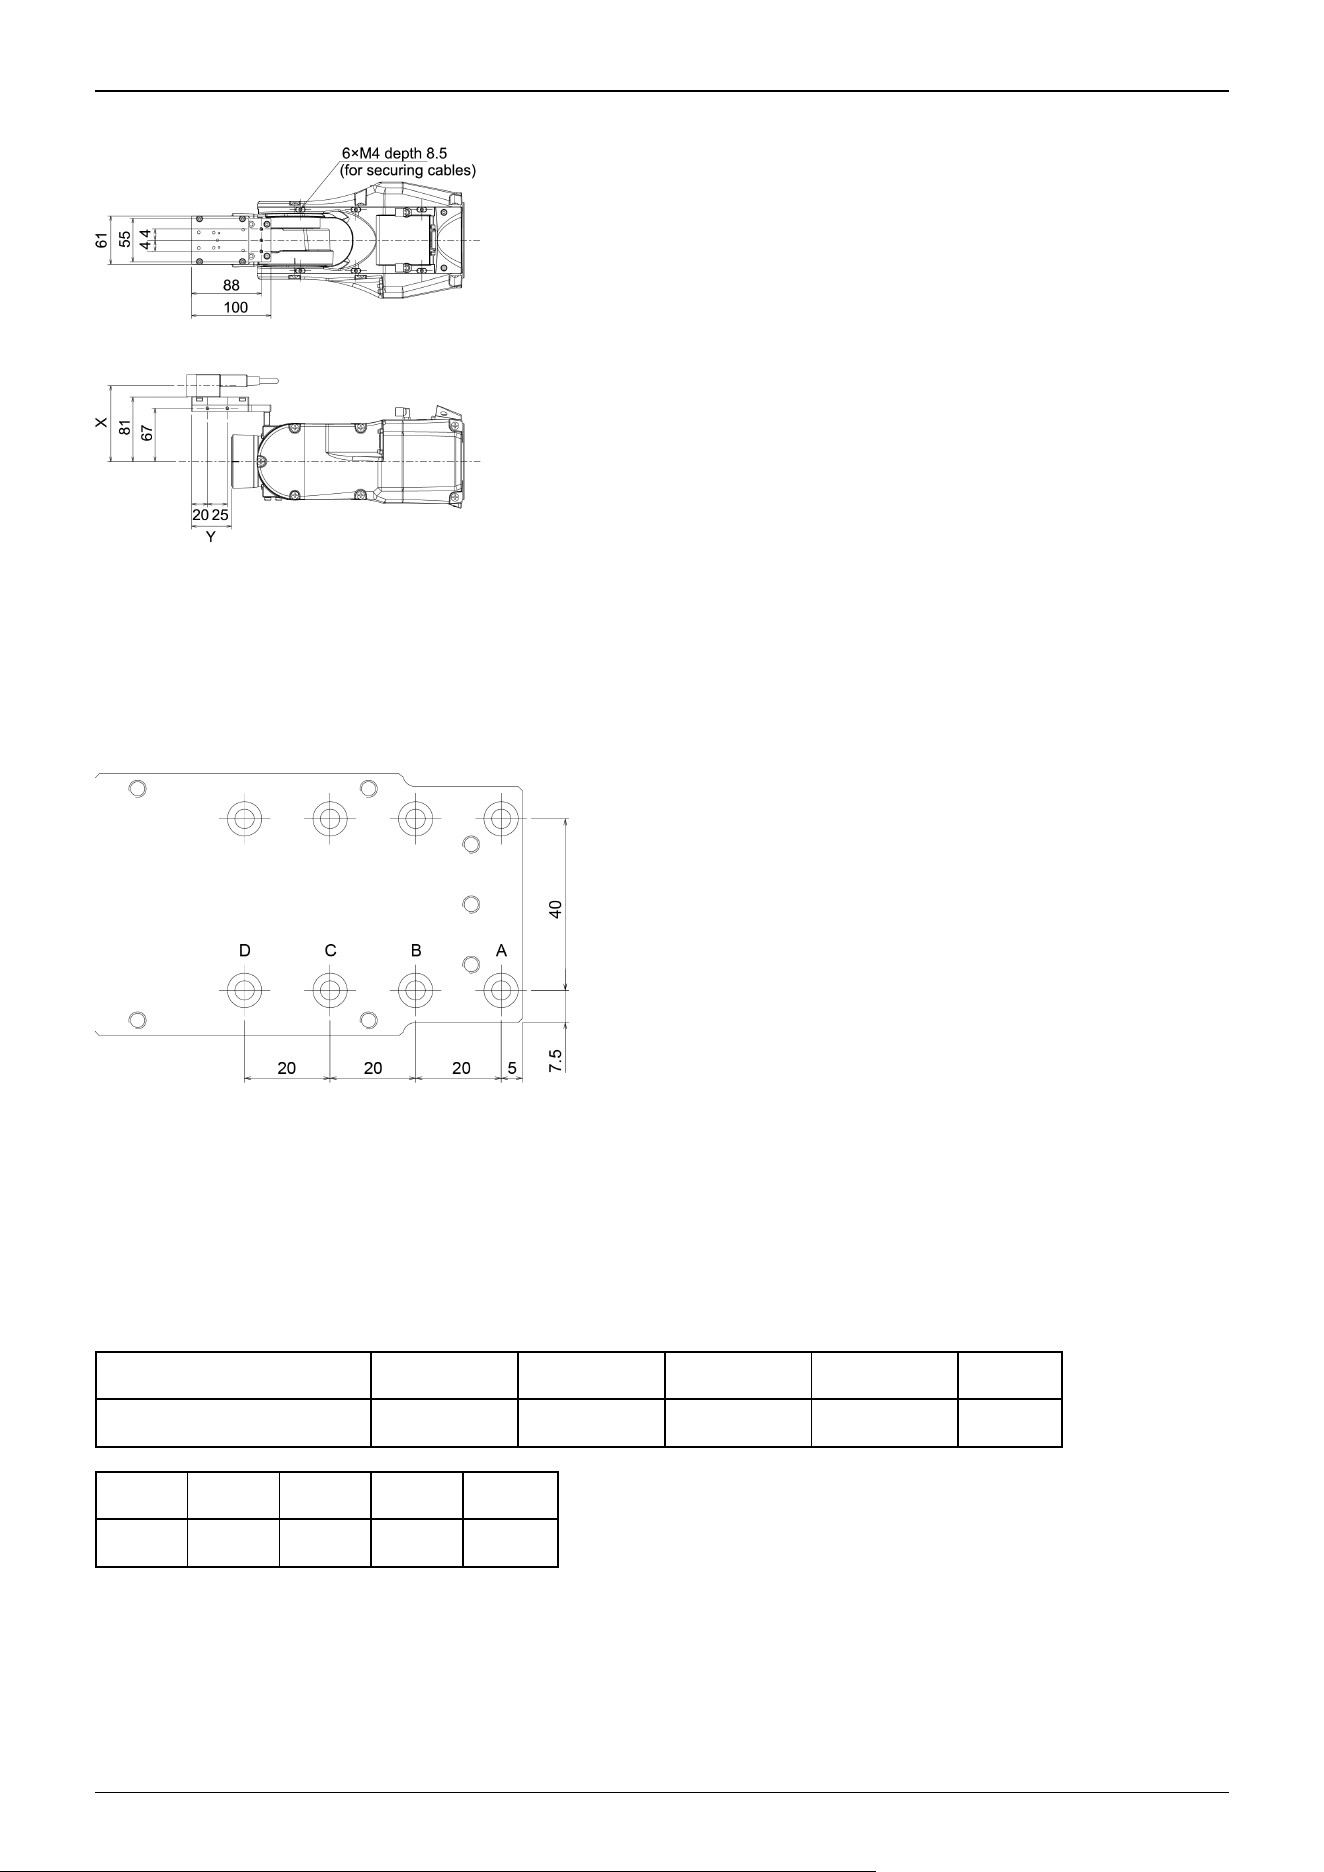
Dimension of the camera plate unit
Dimensions X and Y will change depending on the position of camera mid plate and camera size. Refer to the table below for
the values.
Camera mid plate
The camera mid plate uses the mounting holes A to D. By using the different mounting holes, it can be mounted to the camera
base plate in the different four positions.
Camera and C12 series Manipulator Joint #5 motion range (reference values)
The Joint #5 motion range varies depending on the mounting position of camera mid plate and the camera you are using.
The table below shows the motion range (reference values) based on the available cameras for this option and the mounting
positions of the camera mid plate. The values in the table may vary depending on how to secure the cables.
By changing the Y position, you can extend the distance from the hand mounting surface to the camera. Also, you can attach
the larger hand. However, be careful about the Joint #5 motion range that will be limited in this case.
A B C D X
USB Camera, GigE Camera -135° to +70° -135° to +60° -135° to +45° -135° to +35° 95.5 mm
A B C D
Y 50 mm 30 mm 10 mm -10 mm
Direction of the Joint #5 motion
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
135
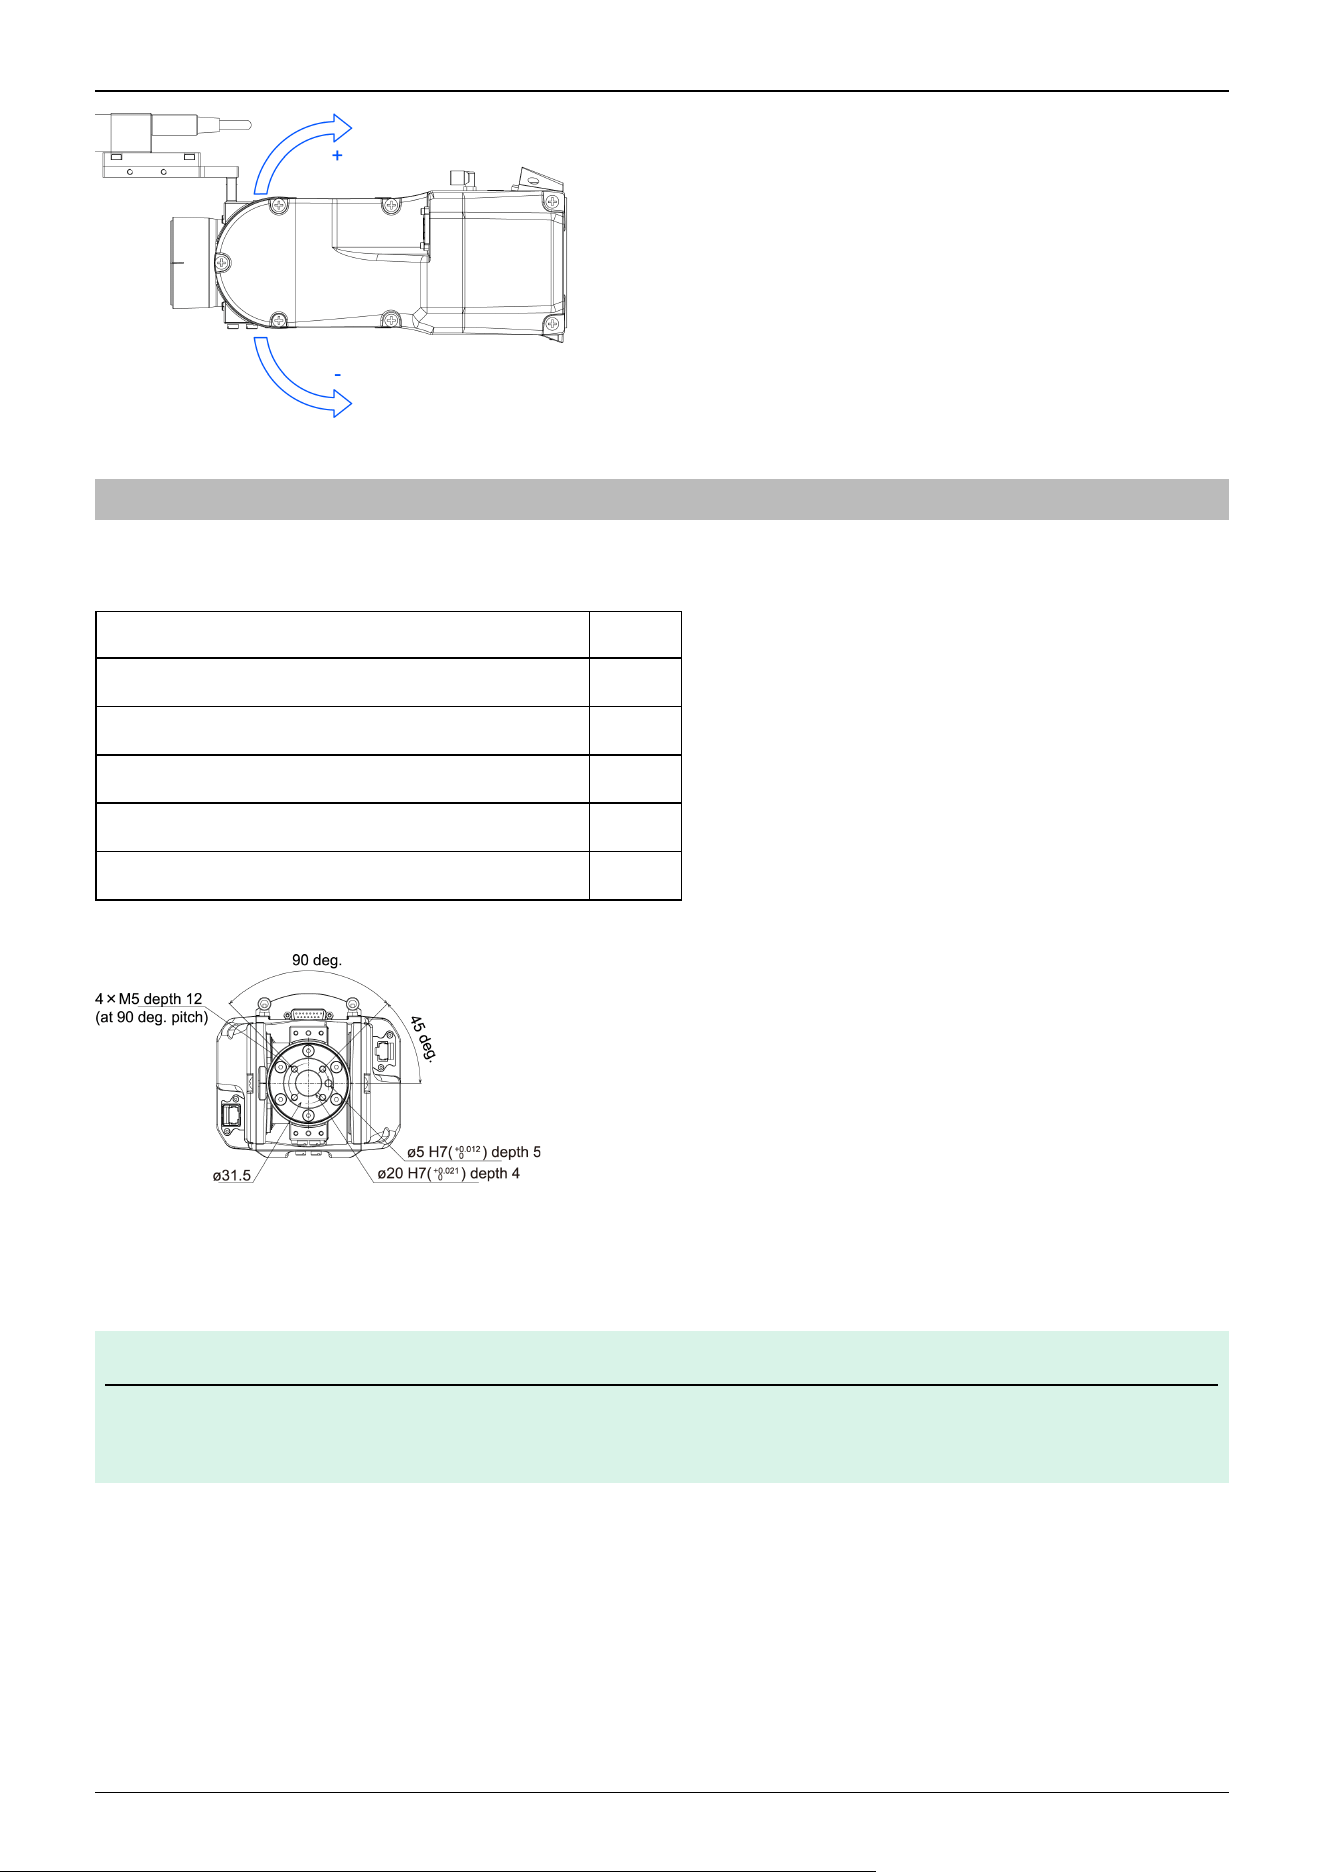
3.6.3 Tool Adapter (ISO flange)
Using the tool adapter, you can mount the hand whose dimensions are designed for the ISO flange to the C12 series
Manipulators.
Parts Included Qty.
ISO flange 1
Flange 1
Pin 2
Hexagon socket head cap bolt with low head M5×10 6
Hexagon socket head cap bolt M5×15 4
Dimensions of ISO flange
* Each dimension and tolerance complies with ISO9409-1-31.5-4-M5.
ISO flange installation
KEY POINTS
For details of tightening the hexagon socket head cap bolt, refer to the following section.
Tightening the Hexagon Socket Head Cap Bolts
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
136
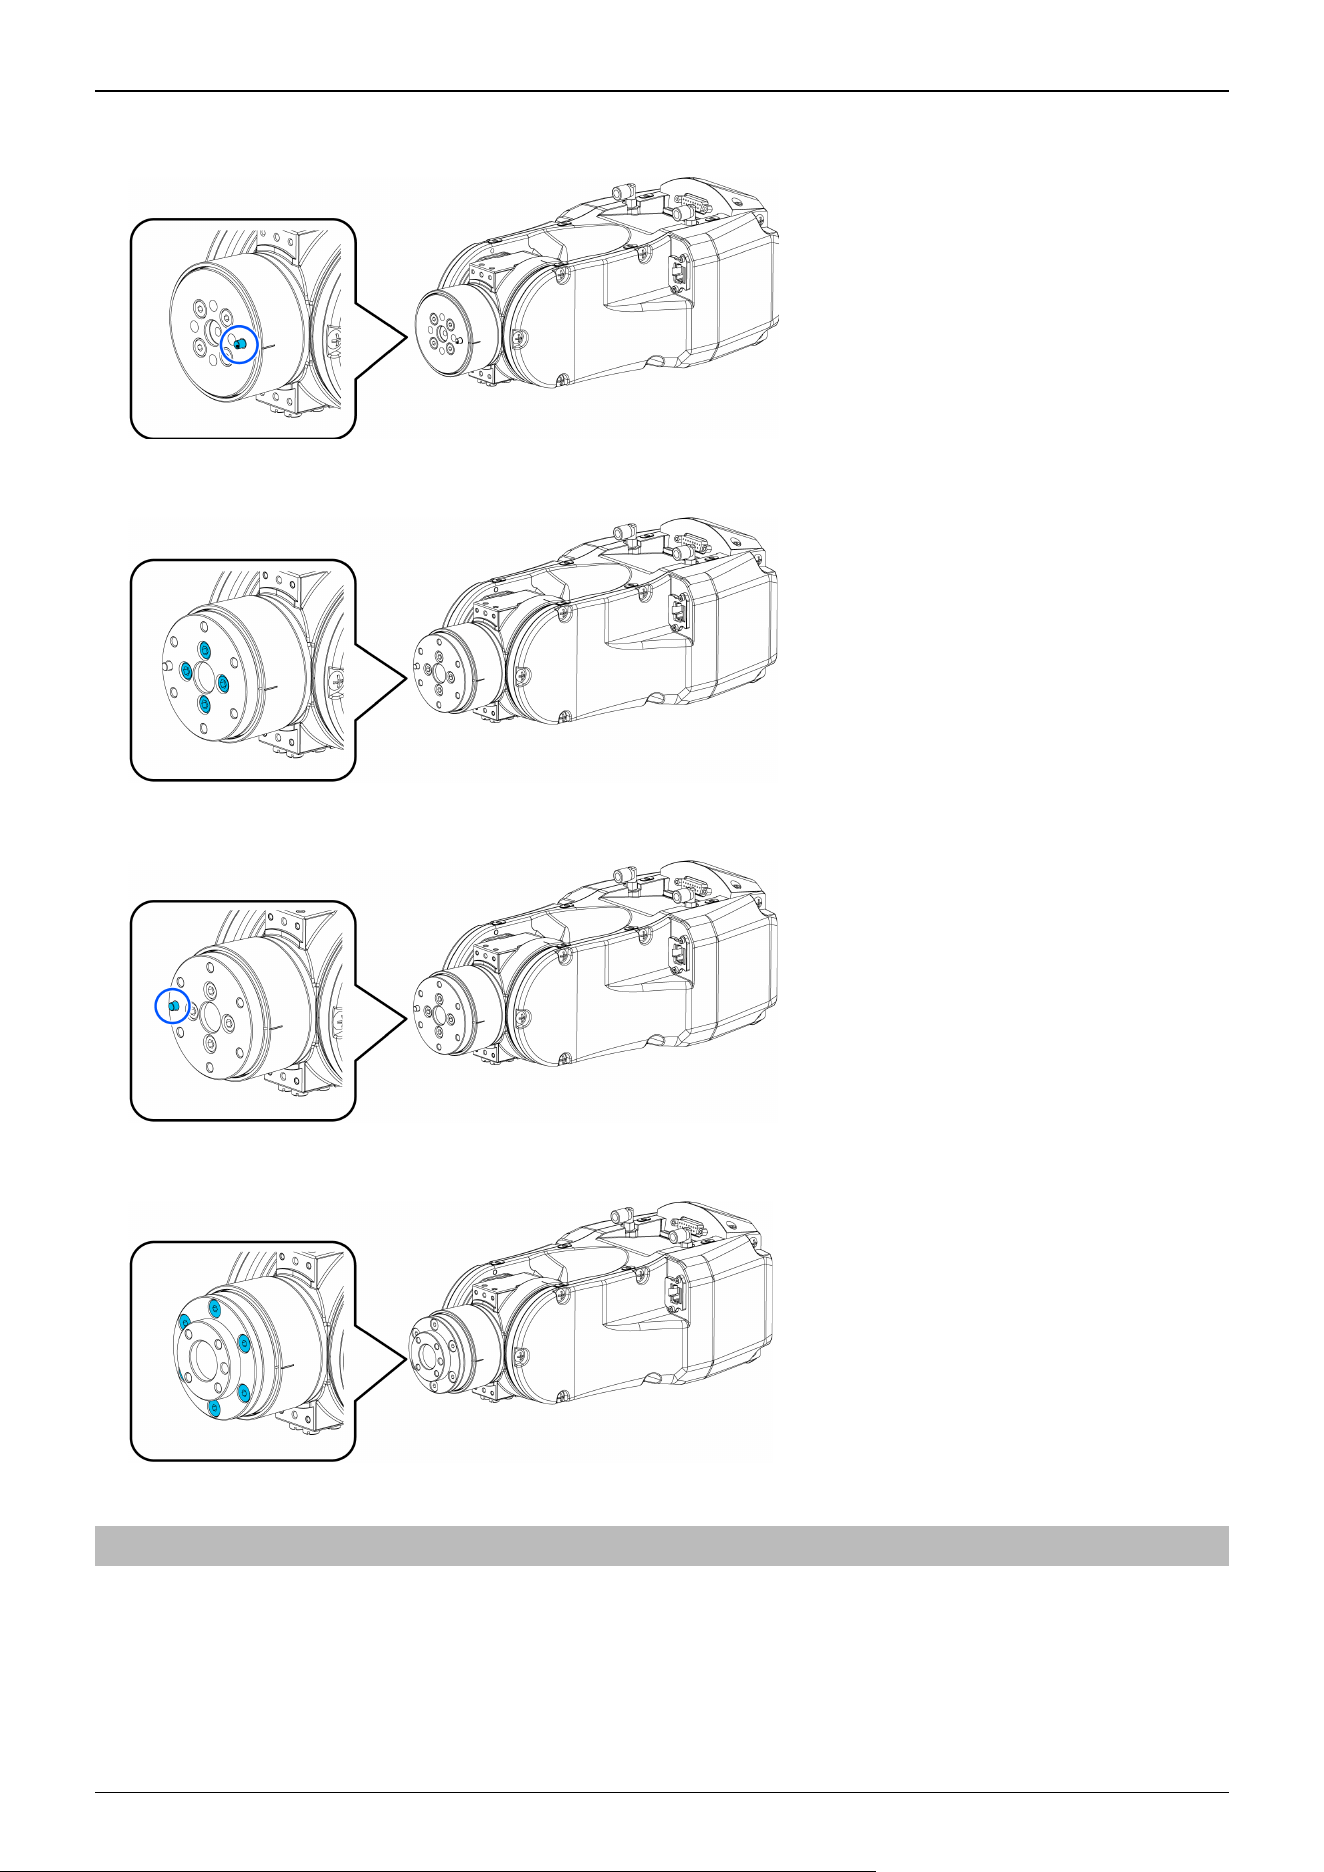
1. Press-fit the pin to the Arm #6 end flange.
Pin protrusion: 4 mm from the flange
2. Align the pin and the pin hole on the flange, and then mount the flange.
Hexagon socket head cap bolt: 4×M5×15
3. Press-fit the pin to the installed flange.
Pin protrusion: 4 mm from the flange
4. Align the pin and the pin hole on the ISO flange, and then mount the ISO flange.
Hexagon socket head cap bolt with low head: 6×M5×10
3.6.4 Variable Mechanical Stop
This option is used to mechanically limit the motion range of the Manipulator.
For installation and angle restriction measures, refer to the following section.
Setting the Work Envelope by Mechanical Stops
Variable Mechanical Stop (J1)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
137
Parts Included Qty.
Variable Mechanical Stop (J1) 1
Hexagon socket head cap bolt M12×30 2
Variable Mechanical Stop (J2)
Parts Included Qty.
Variable Mechanical Stop (J2) 1
Hexagon socket head cap bolt M10×35 2
Variable Mechanical Stop (J3)
Parts Included Qty.
Variable Mechanical Stop (J3) 1
Hexagon socket head cap bolt M6×15 2
3.6.5 User Wires and Pneumatic Tubes
Use the following options when using the internal wiring and tubing for the hand drive.
Attached as standard. The parts can be purchased additionally in case of lost or shortage.
Fitting for Customer Use (
⌀
6 Straight)
Parts Included Qty. Manufacturer Type
⌀6 straight fitting 2 SMC KQ2S06-M6N
Fitting for Customer Use (
⌀
6 Elbow)
Parts Included Qty. Manufacturer Type
⌀6 elbow fitting 2 SMC KQ2L06-M6N
Standard User Connector Kit (D-sub)
Parts Included Qty. Manufacturer Type
Connector 2 JAE DA-15PF-N (Solder type)
Clamp hood 2 HRS HDA-CTH (4-40) (10) (Connector setscrew: #4-40 UNC)
* Attached to standard and cleanroom-model Manipulators as standard. The parts can be purchased additionally in case of lost
or shortage.
Waterproof User Connector Kit (D-sub)
Parts Included Qty. Manufacturer Type
Connector 2 HARTING 09 67 015 5615 (Solder type)
Clamp hood 2 HARTING 09 67 015 0538 (Connector setscrew: #4-40 UNC)
* Attached to the protected-model Manipulators as standard. The parts can be purchased additionally in case of lost or
shortage.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
138
Waterproof User Connector Kit (Ethernet)
Parts Included Qty. Manufacturer Type
Connector 2 HARTING 09 45 145 1560
* Not attached as standard. Please purchase the item if needed. Please note that the protection rating IP67 cannot be satisfied if
other connectors are used.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
139
4. Periodic Inspection
Accurate inspection work is necessary to prevent breakdowns and ensure safety. This section explains the inspection schedule
and what should be inspected.
Perform inspections according to the predetermined schedule.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
140
4.1 C8 Manipulator Periodic Inspection
Accurate inspection work is necessary to prevent breakdowns and ensure safety. This section explains the inspection schedule
and what should be inspected.
Perform inspections according to the predetermined schedule.
4.1.1 Inspection
4.1.1.1 Inspection Schedule
Inspection items are divided into five stages (daily, 1-month, 3-month, 6-month, and 12-month), with additional items added at
each stage. However, if the Manipulator is powered and operated for more than 250 hours in a month, add inspection items
every 250, 750, 1500, and 3000 hours.
Inspection Item
Daily
Inspection
1-month
Inspection
3-month
Inspection
6-month
Inspection
12-month
Inspection
Overhaul (Parts
Replacement)
1 months (250
hours)
Perform
daily
✓
2 months (500
hours)
✓
3 months (750
hours)
✓ ✓
4 months (1,000
hours)
✓
5 months (1,250
hours)
✓
6 months (1,500
hours)
✓ ✓ ✓
7 months (1,750
hours)
✓
8 months (2,000
hours)
✓
9 months (2,250
hours)
✓ ✓
10 months
(2,500 hours)
✓
11 months
(2,750 hours)
✓
12 months
(3,000 hours)
✓ ✓ ✓ ✓
13 months
(3,250 hours)
✓
⁝ ⁝ ⁝ ⁝ ⁝ ⁝ ⁝
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
141
Inspection Item
Daily
Inspection
1-month
Inspection
3-month
Inspection
6-month
Inspection
12-month
Inspection
Overhaul (Parts
Replacement)
(20,000 hours)
✓
4.1.1.2 Inspection Details
Inspection items
Inspection Item Inspection Location
Daily
Inspection
1-month
Inspection
3-month
Inspection
6-month
Inspection
12-month
Inspection
Check for loose or
rattling bolts
Hand mounting bolts
✓ ✓ ✓ ✓ ✓
Manipulator installation
bolts
✓ ✓ ✓ ✓ ✓
Check for loose
connectors
Manipulator side external
(connector plate, etc.)
✓ ✓ ✓ ✓ ✓
Inspect for flaws: Clean
off adhering debris, etc.
Entire Manipulator
✓ ✓ ✓ ✓ ✓
External cables
✓ ✓ ✓ ✓
Correct deformations
and misalignments
Safety barriers, etc. ✓ ✓ ✓ ✓ ✓
Check either the
external short connector
or the brake release unit
connector is connected
The external short
connector on the back
side of the Manipulator,
or the brake release unit
connector
✓ ✓ ✓ ✓ ✓
Check brake operation Brake for Joint #1 to #6
✓ ✓ ✓ ✓ ✓
Check for abnormal
operation noise and
vibration
Entire Manipulator ✓ ✓ ✓ ✓ ✓
Check that fan is
working (only for C8-
C1401*** (C8XL)).
Fan ✓ ✓ ✓ ✓ ✓
Inspection methods
Inspection Item Inspection Method
Check for loose or rattling bolts
Using an Allen wrench or similar tool, check that the hand mounting
bolts and Manipulator installation bolts are not loose.
If the bolts are loose, refer to the following section, and retighten to
the proper torque.
Tightening the Hexagon Socket Head Cap Bolts
Check for loose connectors
Check that no connectors are loose.
If a connector is loose, reattach it so that it will not come off.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
142
Inspection Item Inspection Method
Inspect for flaws: Clean off adhering debris, etc.
Check the appearance of the Manipulator, and clean off any dust or
other foreign substances adhering to it.
Check the appearance of the cables for any flaws, and make sure it is
not disconnected.
Correct deformations and misalignments
Check for misalignment of safety barriers and other components.
If it is misaligned, correct it to the original position.
Check either the external short connector or the
brake release unit connector is connected
Check either the external short connector or the brake release unit
connector is connected.
When it is not connected, connect it.
Check brake operation
With the motor turned off, check that the arm does not drop.
If the arm drops while the motor is turned off and the brake is not
released, contact the supplier.
Check for abnormal operation noise and vibration
Check for any abnormal noises and vibrations during operation.
If you notice anything unusual, contact the supplier.
Check that fan is working (only for C8-C1401***
(C8XL)).
With the motor turned on, check that the fan is working.
If the fan does not work while the motor is turned on, contact the
supplier.
4.1.2 Overhaul (Parts Replacement)
Overhaul (replacement) shall be performed by properly trained service engineers.
For details, refer to the following manual.
"Safety Manual - Role and Training for Safety Managers"
4.1.3 Applying Grease
The reduction gear units and the bevel gear need greasing regularly.
CAUTION
Be careful that the grease does not run out. When grease runs out, scratches and other defects can occur on
the slide, not only hindering maximum performance, but also requiring significant time and money to repair.
If grease enters the eyes or mouth or adheres to the skin, take the following measures:
If it enters the eyes
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
143
After rinsing the eyes thoroughly with clean water, seek medical attention.
If it enters the mouth
If swallowed, do not force vomiting, and seek medical attention. If the mouth is contaminated, rinse
thoroughly with water.
If adhered to skin
Rinse with water and soap.
Part Interval Safety Information
All
joints
Reduction
gear
When overhaul
is performed
Applying grease can only be performed by properly trained service engineers.
For more information, please contact the supplier.
Joint
#6
Bevel
gear
4.1.4 Tightening the Hexagon Socket Head Cap Bolts
Hexagon socket head cap bolts (referred to as "bolts" below) are used in locations where mechanical strength is required.
During assembly, these bolts are tightened at the tightening torques shown in the following table.
Unless otherwise specified, when retightening these bolts in the work procedures described in this manual, use a torque wrench
or similar tool to obtain the tightening torques in the following table.
Bolt Tightening Torque
M3 2.0 ± 0.1 N·m (21 ± 1 kgf·cm)
M4 4.0 ± 0.2 N·m (41 ± 2 kgf·cm)
M5 8.0 ± 0.4 N·m (82 ± 4 kgf·cm)
M6 13.0 ± 0.6 N·m (133 ± 6 kgf·cm)
M8 32.0 ± 1.6 N·m (326 ± 16 kgf·cm)
M10 58.0 ± 2.9 N·m (590 ± 30 kgf·cm)
M12 100.0 ± 5.0 N·m (1,020 ± 51 kgf·cm)
For set screw, refer to the following table.
Set Screw Tightening Torque
M4 2.4 ± 0.1 N·m (26 ± 1 kgf·cm)
M5 3.9 ± 0.2 N·m (40 ± 2 kgf·cm)
M6 8.0 ± 0.4 N·m (82 ± 4 kgf·cm)
It is recommended that bolts arranged in a circular pattern be secured in place by tightening in criss-cross order as shown in the
figure.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
144
Symbol Description
a Threaded holes
When securing the bolts, do not tighten the bolts all at once, but tighten them in two or three separate rounds with an Allen
wrench, and then use a torque wrench or similar tool to secure them at the tightening torques shown in the table above.
4.2 C12 Manipulator Periodic Inspection
Accurate inspection work is necessary to prevent breakdowns and ensure safety. This section explains the inspection schedule
and what should be inspected.
Perform inspections according to the predetermined schedule.
4.2.1 Inspection
4.2.1.1 Inspection Schedule
Inspection items are divided into five stages (daily, 1-month, 3-month, 6-month, and 12-month), with additional items added at
each stage. However, if the Manipulator is powered and operated for more than 250 hours in a month, add inspection items
every 250, 750, 1500, and 3000 hours.
Inspection Item
Daily
Inspection
1-month
Inspection
3-month
Inspection
6-month
Inspection
12-month
Inspection
Overhaul (Parts
Replacement)
1 months (250
hours)
Perform
daily
✓
2 months (500
hours)
✓
3 months (750
hours)
✓ ✓
4 months (1,000
hours)
✓
5 months (1,250
hours)
✓
6 months (1,500
hours)
✓ ✓ ✓
7 months (1,750
hours)
✓
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
145
Inspection Item
Daily
Inspection
1-month
Inspection
3-month
Inspection
6-month
Inspection
12-month
Inspection
Overhaul (Parts
Replacement)
8 months (2,000
hours)
✓
9 months (2,250
hours)
✓ ✓
10 months
(2,500 hours)
✓
11 months
(2,750 hours)
✓
12 months
(3,000 hours)
✓ ✓ ✓ ✓
13 months
(3,250 hours)
✓
⁝ ⁝ ⁝ ⁝ ⁝ ⁝ ⁝
(20,000 hours)
✓
4.2.1.2 Inspection Details
Inspection items
Inspection Item Inspection Location
Daily
Inspection
1-month
Inspection
3-month
Inspection
6-month
Inspection
12-month
Inspection
Check for loose or
rattling bolts
Hand mounting bolts
✓ ✓ ✓ ✓ ✓
Manipulator installation
bolts
✓ ✓ ✓ ✓ ✓
Check for loose
connectors
Manipulator side external
(connector plate, etc.)
✓ ✓ ✓ ✓ ✓
Inspect for flaws: Clean
off adhering debris, etc.
Entire Manipulator
✓ ✓ ✓ ✓ ✓
External cables
✓ ✓ ✓ ✓
Correct deformations
and misalignments
Safety barriers, etc. ✓ ✓ ✓ ✓ ✓
Check either the
external short connector
or the brake release unit
connector is connected
The external short
connector on the back
side of the Manipulator,
or the brake release unit
connector
✓ ✓ ✓ ✓ ✓
Check brake operation Brake for Joint #1 to #6
✓ ✓ ✓ ✓ ✓
Check for abnormal
operation noise and
vibration
Entire Manipulator ✓ ✓ ✓ ✓ ✓
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
146
Inspection Item Inspection Location
Daily
Inspection
1-month
Inspection
3-month
Inspection
6-month
Inspection
12-month
Inspection
Check that fan is
working.
Fan ✓ ✓ ✓ ✓ ✓
Inspection methods
Inspection Item Inspection Method
Check for loose or rattling bolts
Using an Allen wrench or similar tool, check that the hand mounting
bolts and Manipulator installation bolts are not loose.
If the bolts are loose, refer to the following section, and retighten to
the proper torque.
Tightening the Hexagon Socket Head Cap Bolts
Check for loose connectors
Check that no connectors are loose.
If a connector is loose, reattach it so that it will not come off.
Inspect for flaws: Clean off adhering debris, etc.
Check the appearance of the Manipulator, and clean off any dust or
other foreign substances adhering to it.
Check the appearance of the cables for any flaws, and make sure it is
not disconnected.
Correct deformations and misalignments
Check for misalignment of safety barriers and other components.
If it is misaligned, correct it to the original position.
Check either the external short connector or the
brake release unit connector is connected
Check either the external short connector or the brake release unit
connector is connected.
When it is not connected, connect it.
Check brake operation
With the motor turned off, check that the arm does not drop.
If the arm drops while the motor is turned off and the brake is not
released, contact the supplier.
Check for abnormal operation noise and vibration
Check for any abnormal noises and vibrations during operation.
If you notice anything unusual, contact the supplier.
Check that fan is working.
With the motor turned on, check that the fan is working.
If the fan does not work while the motor is turned on, contact the
supplier.
4.2.2 Overhaul (Parts Replacement)
Overhaul (replacement) shall be performed by properly trained service engineers.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
147
For details, refer to the following manual.
"Safety Manual - Role and Training for Safety Managers"
4.2.3 Applying Grease
The reduction gear units and the bevel gear need greasing regularly.
CAUTION
Be careful that the grease does not run out. When grease runs out, scratches and other defects can occur on
the slide, not only hindering maximum performance, but also requiring significant time and money to repair.
If grease enters the eyes or mouth or adheres to the skin, take the following measures:
If it enters the eyes
After rinsing the eyes thoroughly with clean water, seek medical attention.
If it enters the mouth
If swallowed, do not force vomiting, and seek medical attention. If the mouth is contaminated, rinse
thoroughly with water.
If adhered to skin
Rinse with water and soap.
Part Interval Safety Information
All
joints
Reduction
gear
When overhaul
is performed
Applying grease can only be performed by properly trained service engineers.
For more information, please contact the supplier.
Joint
#6
Bevel
gear
4.2.4 Tightening the Hexagon Socket Head Cap Bolts
Hexagon socket head cap bolts (referred to as "bolts" below) are used in locations where mechanical strength is required.
During assembly, these bolts are tightened at the tightening torques shown in the following table.
Unless otherwise specified, when retightening these bolts in the work procedures described in this manual, use a torque wrench
or similar tool to obtain the tightening torques in the following table.
Bolt Tightening Torque
M3 2.0 ± 0.1 N·m (21 ± 1 kgf·cm)
M4 4.0 ± 0.2 N·m (41 ± 2 kgf·cm)
M5 8.0 ± 0.4 N·m (82 ± 4 kgf·cm)
M6 13.0 ± 0.6 N·m (133 ± 6 kgf·cm)
M8 32.0 ± 1.6 N·m (326 ± 16 kgf·cm)
M10 58.0 ± 2.9 N·m (590 ± 30 kgf·cm)
M12 100.0 ± 5.0 N·m (1,020 ± 51 kgf·cm)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
148
For set screw, refer to the following table.
Set Screw Tightening Torque
M4 2.4 ± 0.1 N·m (26 ± 1 kgf·cm)
M5 3.9 ± 0.2 N·m (40 ± 2 kgf·cm)
M6 8.0 ± 0.4 N·m (82 ± 4 kgf·cm)
It is recommended that bolts arranged in a circular pattern be secured in place by tightening in criss-cross order as shown in the
figure.
Symbol Description
a Threaded holes
When securing the bolts, do not tighten the bolts all at once, but tighten them in two or three separate rounds with an Allen
wrench, and then use a torque wrench or similar tool to secure them at the tightening torques shown in the table above.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
149
5. Appendix
This section provides detailed technical data such as the specifications, stopping time, and stopping distance for each model.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
150
5.1 Appendix A: Specifications Table
5.1.1 C8 Specifications
Item
Specifications
C8-C901 *** C8-C1401***
Machinery name Industrial robot
Product series C-C
Model
C8-C901 ***
Model Number
C8-C1401***
Model Number
Model Name C8L C8XL
Mounting type *1
Table top mounting, Ceiling
mounting, Wall mounting
Arm length P point: J1 to J5 center 901.1 1400.6
Maximum reach J1 to J6 flange 981.1 1480.6
Manipulator weight (not include the
weight of cables or shipping jigs)
Standard, cleanroom & ESD specifications 53 kg: 117 lb 63 kg: 139 lb
Protected-Model 57 kg: 126 lb 66 kg: 146 lb
Drive system All joints AC servo motor
Maximum operating speed *2
Joint #1 294°/s 200°/s
Joint #2 300°/s 167°/s
Joint #3 360°/s 200°/s
Joint #4 480°/s
Joint #5 450°/s
Joint #6 720°/s
Maximum synthetic speed 9679 mm/s 8858 mm/s
Repeatability Joint #1 to #6 ±0.03 mm ±0.05 mm
Maximum motion range
Joint #1 ±240°
Joint #2 -158° to +65° -135° to +55°
Joint #3 -61° to +202°
Joint #4 ±200°
Joint #5 ±135°
Joint #6 ±540° *3
Max. pulse range (pulse)
Joint #1 ±10695600 ±15736800
Joint #2
-6903178 to
+2839915
-10616940 to
+4325420
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
151
Item
Specifications
C8-C901 *** C8-C1401***
Joint #3
-2220949 to
+7354618
-3997696 to
+13238272
Joint #4 ±5461400
Joint #5 ±3932280
Joint #6 ±9830400
Resolution
Joint #1 0.0000224°/pulse 0.0000153°/pulse
Joint #2 0.0000229°/pulse 0.0000127°/pulse
Joint #3 0.0000275°/pulse 0.0000153°/pulse
Joint #4 0.0000366°/pulse
Joint #5 0.0000343°/pulse
Joint #6 0.0000549°/pulse
Motor rated capacity
Joint #1 1000 W
Joint #2 750 W
Joint #3 400 W
Joint #4 100 W
Joint #5 100 W
Joint #6 100 W
Payload (load) *4
Rated 3 kg
Maximum 8 kg
Allowable moment
Joint #4 16.6 N·m (1.69 kgf·m)
Joint #5 16.6 N·m (1.69 kgf·m)
Joint #6 9.4 N·m (0.96 kgf·m)
Allowable moment of inertia *5
(GD
2
/4)
Joint #4
0.47 kg·m
2
Joint #5
0.47 kg·m
2
Joint #6
0.15 kg·m
2
User wires
15 wires (D-sub)
8 pin (RJ45) equivalent to Cat.5e
6 pin (for Force Sensor)
User wires *6
⌀6 mm pneumatic tube × 2
Pressure resistance: 0.59 MPa (6
kgf/cm
2
) (86 psi)
Environmental requirements *7
Ambient temperature 5 to 40°C *8
Ambient relative humidity 10 to 80% RH (no condensation)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
152
Item
Specifications
C8-C901 *** C8-C1401***
Vibration
4.9 m/s
2
(0.5 G) or less
Transportation and storage
Temperature −20 to +60°C
Humidity 10 to 90% (no condensation)
Noise level *9
LAeq = 74.9 dB
(A) or lower
LAeq = 78 dB
(A) or lower
Environmental Specifications
Standard *10
Cleanroom & ESD *10
Protection (IP67) *11
Compatible Controller RC800-A
M/C cable
Cable weight
(cable only)
For fixing and signal
(common to all lengths)
0.06 kg/m
For fixing and power
(common to all lengths)
0.45 kg/m
For movable and signal
(common to all lengths)
0.07 kg/m
For movable and power
(common to all lengths)
0.52 kg/m
Cable outer
diameter
For fixing and signal
(common to all lengths)
⌀6.2 mm (typ)
For fixing and power
(common to all lengths)
⌀17.8 mm (typ)
For movable and signal
(common to all lengths)
⌀6.4 mm (typ)
For movable and power
(common to all lengths)
⌀17.8 mm (typ)
Minimum
bending radius
*12
For fixing and signal
(common to all lengths)
38 mm
For fixing and power
(common to all lengths)
107 mm
For movable and signal
(common to all lengths)
100 mm
For movable and power
(common to all lengths)
100 mm
Setting value range
( )Default value
Speed
1
〜(3)〜100
Accel *13
1
〜(5)〜120
SpeedS
0.1
〜(50)〜2000
AccelS *14
0.1
〜(200)〜
35000
0.1
〜(120)〜
25000
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
153
Item
Specifications
C8-C901 *** C8-C1401***
Fine
0
〜(10000)〜131070
Weight
0
〜(3)〜8
Inertia
0
〜(0.03)〜0.15
*1: Mounting types other than Table top mounting, Ceiling mounting, and Wall mounting are out of specification.
*2: When PTP statements are used
*3: The motion range of J6 can be set to ±540° to 3600°.Rotation limits differ depending on the model.Be sure to contact the
supplier if you would like to set it to a range higher than the above.
*4: Do not apply the load exceeding the maximum payload.
*5: If the center of gravity is at the center of each arm. If the center of gravity is not at the center of each arm, set the
eccentricity using INERTIA command.
*6: For details of the installed pneumatic tube for customer use, refer to the following section.
User Wires and Pneumatic Tubes
*7: For details of the environmental requirements, refer to the following section.
Environment
*8: When used in a low-temperature environment near the minimum temperature specified in the product specifications, or
when the unit is idle for a long period of time during holidays or at night, a collision detection error or similar error may occur
immediately after the start of operation due to high resistance in the drive unit. In such cases, warm-up operation for about 10
minutes is recommended.
*9: The conditions at measurement are as follows.
Operating conditions: Under rated load, all arms simultaneous motion, maximum speed, and maximum
acceleration/deceleration which duty is 100%.
Measurement point: 1000 mm apart from the rear of Manipulator
*10: Manipulators with cleanroom specifications discharge the exhaust inside of the base and inside of the arm cover section
together. Consequently, if there is a gap in the base section, the arm tip section will not be sufficiently negatively pressurized,
which may result in dust generation.
Cleanliness level:
C8L: ISO Class 3 (ISO14644-1)
C8XL: ISO Class 4 (ISO14644-1)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
154
Exhaust port: Fitting for ⌀12 mm tube 60 L/min vacuum
Exhaust tube: Polyurethane tube Outer diameter: ⌀12 mm
ESD specification uses resin materials with anti-static treatment. This model controls adhesion of dust due to electrification.
Protection level for the standard model and cleanroom model Manipulators is equivalent to IP20.
The IP (International Protection) rating is an international standard indicating the degree of protection against dust and water.
Protection Class
IP20
Dust protection level:
2
A solid object which is 12.5 mm or longer cannot touch dangerous areas inside of the
Manipulator.
Water protection
level: 0
Not protected.
*11: Protection level for the protected-model Manipulators is IP67 (IEC standard). The Manipulators can be used in
environments where the possibility of dust, water, and water-soluble cutting oil falling of the Manipulator exists. Note the
following points.
The Manipulator is not rust-proofed. Do not use the Manipulator in environment where corrosive liquids exist.
Fluids that deteriorate the sealing materials, such as organic solvents, acids, alkalis, and chlorine cutting fluids, cannot be
used.
The Manipulator cannot be used for underwater operations.
The Controller does not have protection features against the environment (Controller’s protection level: IP20). Make sure
to install the system where environmental requirements for the Controller are satisfied.
The fan cover is equivalent to IP 20.
Be sure to connect a connector compliant with protection class IP67 or higher and a connector cover to the Ethernet cable
connector.
The IP (International Protection) rating is an international standard indicating the degree of protection against dust and water.
Protection Class
IP20
Dust
protection
level: 2
A solid object which is 12.5 mm or longer cannot touch dangerous areas inside of the Manipulator.
Water
protection
level: 0
Not protected.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
155
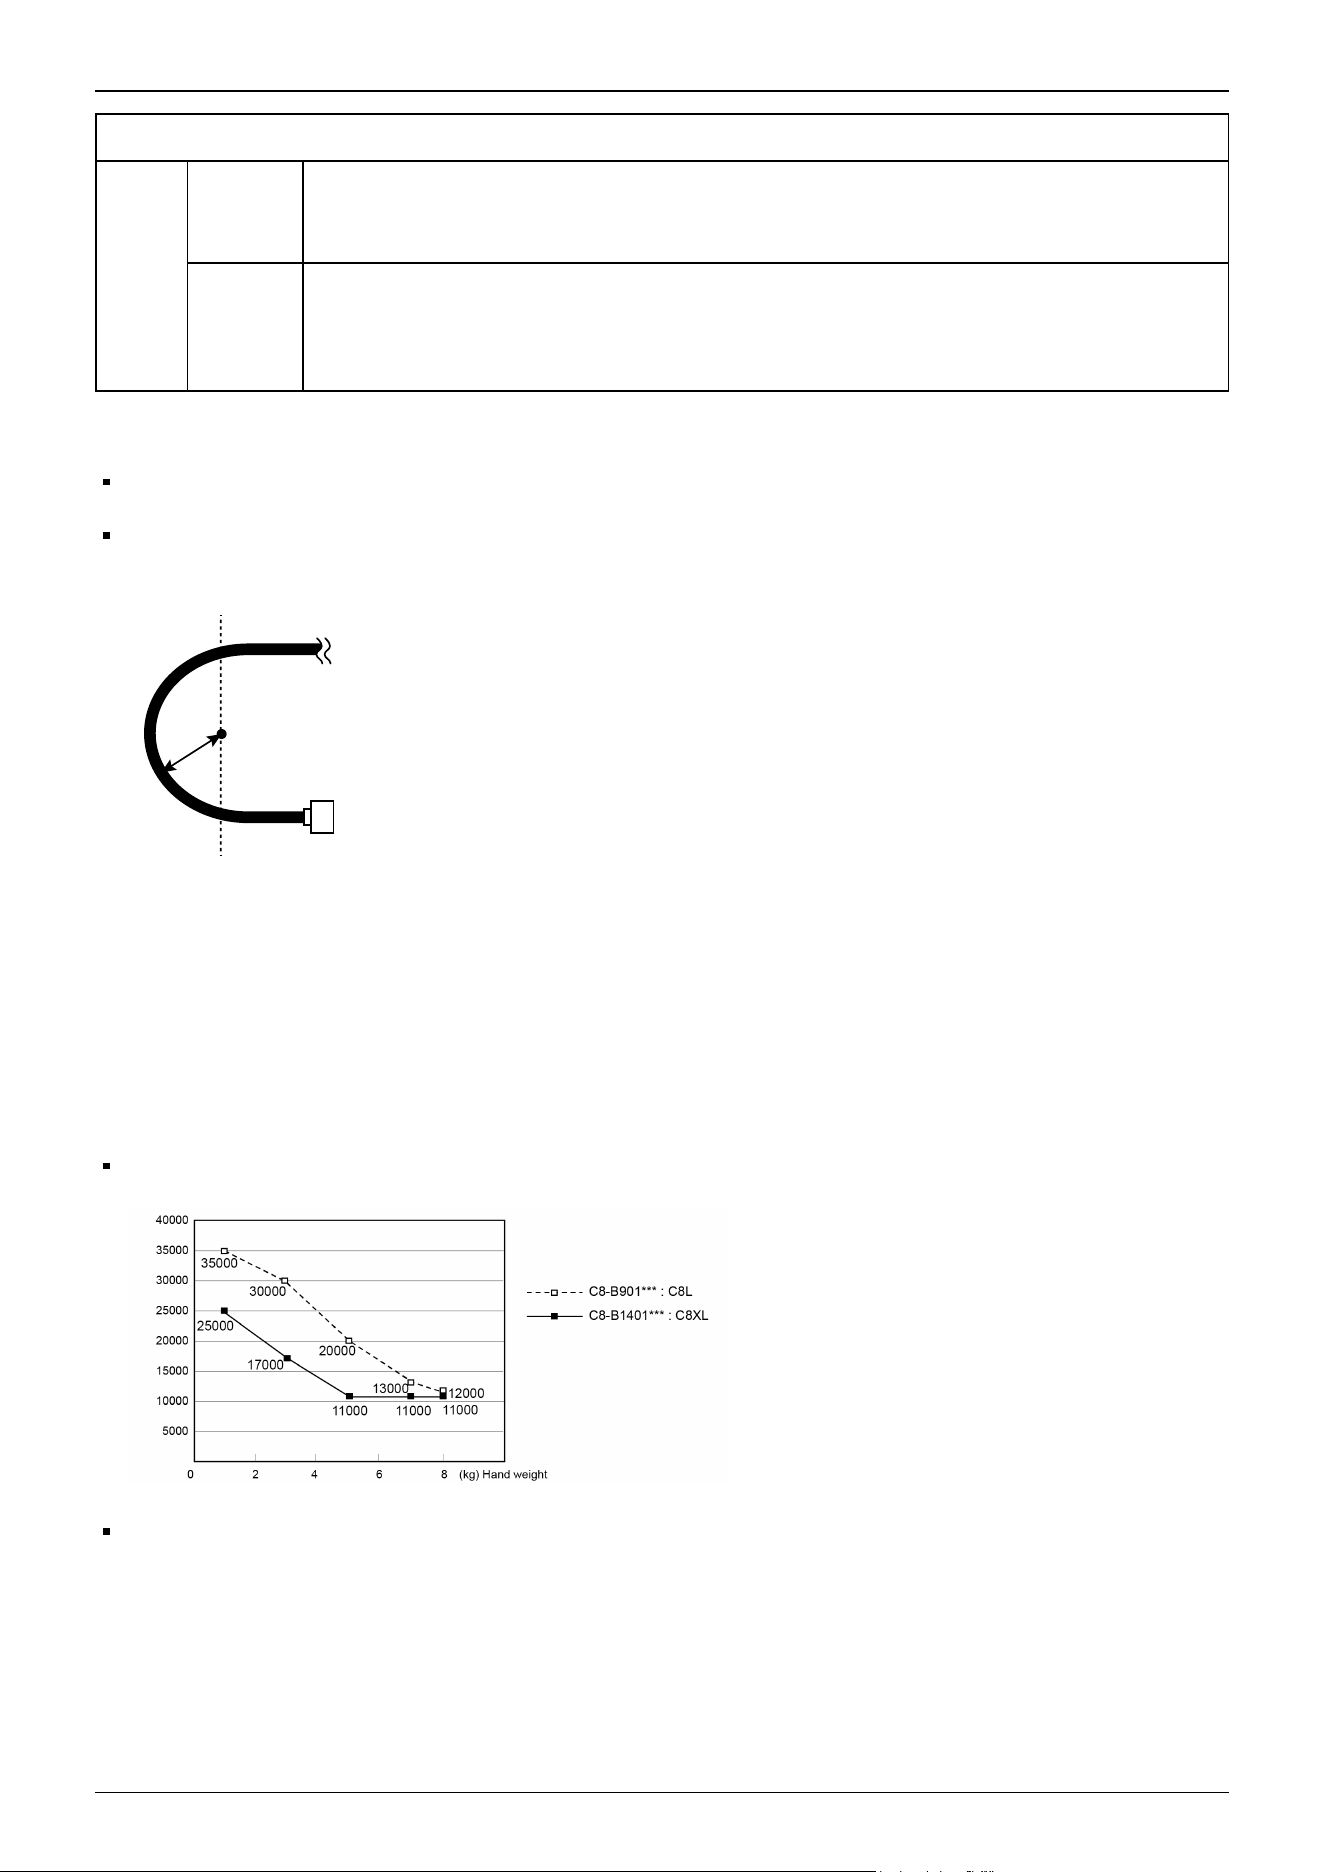
Protection Class
IP67
Dust
protection
level: 6
A testing rod which is 1.0 mm or longer cannot touch dangerous areas inside of the Manipulator.
Totally protected against dust.
Water
protection
level: 7
Water cannot enter the Manipulator when the Manipulator is immersed in water for 30 minutes under
the condition that the highest point of the Manipulator is located 0.15 m below the surface of the
water and the lowest point is located 1 m below the surface of the water. (The Manipulator is stopped
during the test.)
*12: Note the following points when wiring the movable M/C cable.
Install the cable not to apply a load to the connector.
Bend the cable at the minimum bending radius of the movable part or more. The bending radius (a) and dimensions are
shown in the figure below.
*13: The Accel setting of "100" is the optimum setting that balances acceleration/deceleration and vibration during positioning.
Although values larger than 100 can be set to Accel, it is recommended to minimize the use of large values to necessary
motions since operating the Manipulator continuously with the large Accel setting may shorten the product life remarkably.
*14: Maximum AccelS setting value varies depending on the load. For details, refer to the following figure. Setting the value
which exceeds the maximum AccelS causes an error. Check the setting value.
Maximum AccelS setting value
Table top mounting, Ceiling mounting
Wall mounting
M/C cable
Connector
a
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
156
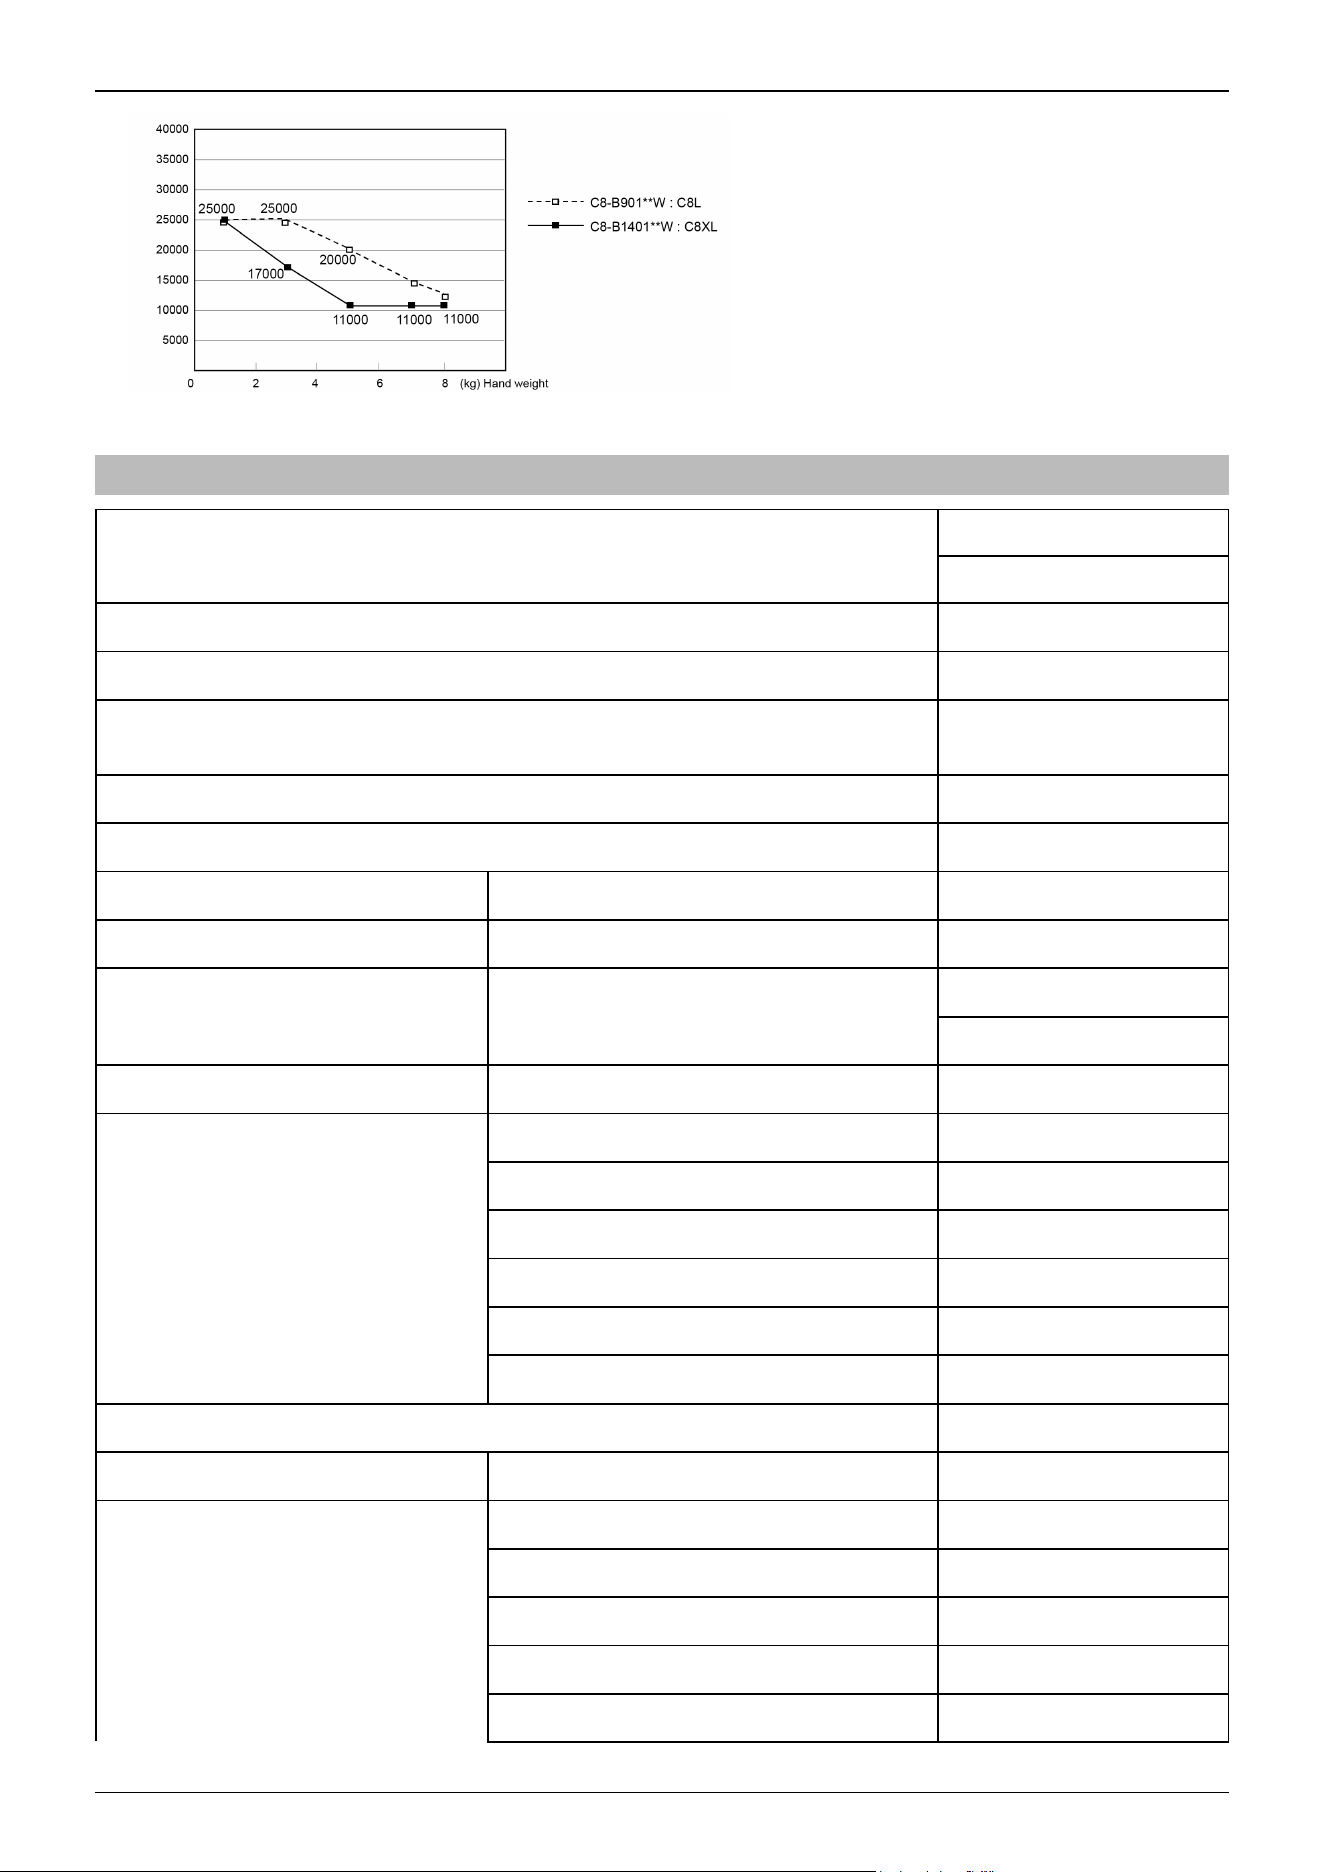
5.1.2 C12 Specifications
Item
Specifications
C12-C1401**
Machinery name Industrial robot
Product series C-C
Model
C12-C1401**
Model Number
Model Name C12XL
Mounting type *1 Table top mounting
Arm length P point: J1 to J5 center 1400.6
Maximum reach J1 to J6 flange 1480.6
Manipulator weight (not include the
weight of cables or shipping jigs)
Standard model
Cleanroom & ESD model
63 kg: 139 lb
67 kg: 148 lb
Drive system All joints AC servo motor
Maximum operating speed *2
Joint #1 200°/s
Joint #2 167°/s
Joint #3 200°/s
Joint #4 300°/s
Joint #5 360°/s
Joint #6 720°/s
Maximum synthetic speed 8751 mm/s
Repeatability Joint #1 to #6 ±0.05 mm
Maximum motion range
Joint #1 ±240°
Joint #2 -135 to +55°
Joint #3 -61 to +202°
Joint #4 ±200°
Joint #5 ±135°
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
157
Item
Specifications
C12-C1401**
Joint #6 ±540° *3
Max. pulse range (pulse)
Joint #1 ±15736800
Joint #2 -10616940 to +4325420
Joint #3 -3997696 to +13238272
Joint #4 ±8738240
Joint #5 ±4915350
Joint #6 ±9830400
Resolution
Joint #1 0.0000153°/pulse
Joint #2 0.0000127°/pulse
Joint #3 0.0000153°/pulse
Joint #4 0.0000229°/pulse
Joint #5 0.0000275°/pulse
Joint #6 0.0000549°/pulse
Motor rated capacity
Joint #1 1000 W
Joint #2 750 W
Joint #3 400 W
Joint #4 150 W
Joint #5 150 W
Joint #6 150 W
Payload (load) *4
Rated 3 kg
Maximum 12 kg
Allowable moment
Joint #4 25.0 N·m (2.55 kgf·m)
Joint #5 25.0 N·m (2.55 kgf·m)
Joint #6 9.8 N·m (1.0 kgf·m)
Allowable moment of inertia *5 (GD
2
/4)
Joint #4
0.70 kg·m
2
Joint #5
0.70 kg·m
2
Joint #6
0.20 kg·m
2
User wires
15 wires (D-sub)
8 pin (RJ45) equivalent to
Cat.5e
6 pin (for Force Sensor)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
158
Item
Specifications
C12-C1401**
User wires *6
⌀6 mm pneumatic tube × 2
Pressure resistance: 0.59
MPa (6 kgf/cm
2
) (86 psi)
Environmental requirements *7
Ambient temperature 5 to 40°C *8
Ambient relative humidity
10 to 80% RH (no
condensation)
Vibration
4.9 m/s
2
(0.5 G) or less
Transportation and storage
Temperature −20 to +60°C
Humidity
10 to 90% (no condensation)
Noise level *9 LAeq = 79.6 dB (A) or lower
Environmental specifications *10
Standard
Cleanroom & ESD
Protection(IP67) *11
Compatible Controller RC800-A
M/C cable
Cable weight
(cable only)
For fixing and signal
(common to all lengths)
0.06 kg/m
For fixing and power
(common to all lengths)
0.45 kg/m
For movable and signal
(common to all lengths)
0.07 kg/m
For movable and power
(common to all lengths)
0.52 kg/m
Cable outer
diameter
For fixing and signal
(common to all lengths)
⌀6.2 mm (typ)
For fixing and power
(common to all lengths)
⌀17.8 mm (typ)
For movable and signal
(common to all lengths)
⌀6.4 mm (typ)
For movable and power
(common to all lengths)
⌀17.8 mm (typ)
Minimum
bending radius
*12
For fixing and signal
(common to all lengths)
38 mm
For fixing and power
(common to all lengths)
107 mm
For movable and signal
(common to all lengths)
100 mm
For movable and power
(common to all lengths)
100 mm
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
159
Item
Specifications
C12-C1401**
Setting value range
( )Default value
Speed
1
〜(3)〜100
Accel *13
1
〜(5)〜120
SpeedS
0.1
〜(50)〜2000
AccelS *14
0.1
〜(120)〜25000
Fine
0
〜(10000)〜131070
Weight
0
〜(3)〜12
Inertia
0
〜(0.03)〜0.2
*1: Mounting types other than Table top mounting are out of specification.
*2: When PTP statements are used
*3: The motion range of J6 can be set to ±540° to 3600°.Rotation limits differ depending on the model.Be sure to contact the
supplier if you would like to set it to a range higher than the above.
*4: Do not apply the load exceeding the maximum payload.
*5: If the center of gravity is at the center of each arm. If the center of gravity is not at the center of each arm, set the
eccentricity using INERTIA command.
*6: For details of the installed pneumatic tube for customer use, refer to the following section.
User Wires and Pneumatic Tubes
*7: For details of the environmental requirements, refer to the following section.
Environment
*8: When used in a low-temperature environment near the minimum temperature specified in the product specifications, or
when the unit is idle for a long period of time during holidays or at night, a collision detection error or similar error may occur
immediately after the start of operation due to high resistance in the drive unit. In such cases, warm-up operation for about 10
minutes is recommended.
*9: The conditions at measurement are as follows.
Operating conditions: Under rated load, all arms simultaneous motion, maximum speed, and maximum
acceleration/deceleration which duty is 100%.
Measurement point: 1000 mm apart from the rear of Manipulator
*10: Manipulators with cleanroom specifications discharge the exhaust inside of the base and inside of the arm cover section
together. Consequently, if there is a gap in the base section, the arm tip section will not be sufficiently negatively pressurized,
which may result in dust generation.
Cleanliness: ISO Class 4 (ISO 14644-1)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
160
Exhaust port: Fitting for ⌀12 mm tube 60 L/min vacuum
Exhaust tube: Polyurethane tube Outer diameter: ⌀12 mm
ESD specification uses resin materials with anti-static treatment. This model controls adhesion of dust due to electrification.
Protection level for the standard model and cleanroom model Manipulators is equivalent to IP20.
The IP (International Protection) rating is an international standard indicating the degree of protection against dust and water.
Protection Class
IP20
Dust protection level:
2
A solid object which is 12.5 mm or longer cannot touch dangerous areas inside of the
Manipulator.
Water protection
level: 0
Not protected.
*11: Protection level for the protected-model Manipulators is IP67 (IEC standard). The Manipulators can be used in
environments where the possibility of dust, water, and water-soluble cutting oil falling of the Manipulator exists. Note the
following points.
The Manipulator is not rust-proofed. Do not use the Manipulator in environment where corrosive liquids exist.
Fluids that deteriorate the sealing materials, such as organic solvents, acids, alkalis, and chlorine cutting fluids, cannot be
used.
The Manipulator cannot be used for underwater operations.
The Controller does not have protection features against the environment (Controller’s protection level: IP20). Make sure
to install the system where environmental requirements for the Controller are satisfied.
The fan cover is equivalent to IP 20.
Be sure to connect a connector compliant with protection class IP67 or higher and a connector cover to the Ethernet cable
connector.
The IP (International Protection) rating is an international standard indicating the degree of protection against dust and water.
Protection Class
IP20
Dust
protection
level: 2
A solid object which is 12.5 mm or longer cannot touch dangerous areas inside of the Manipulator.
Water
protection
level: 0
Not protected.
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
161
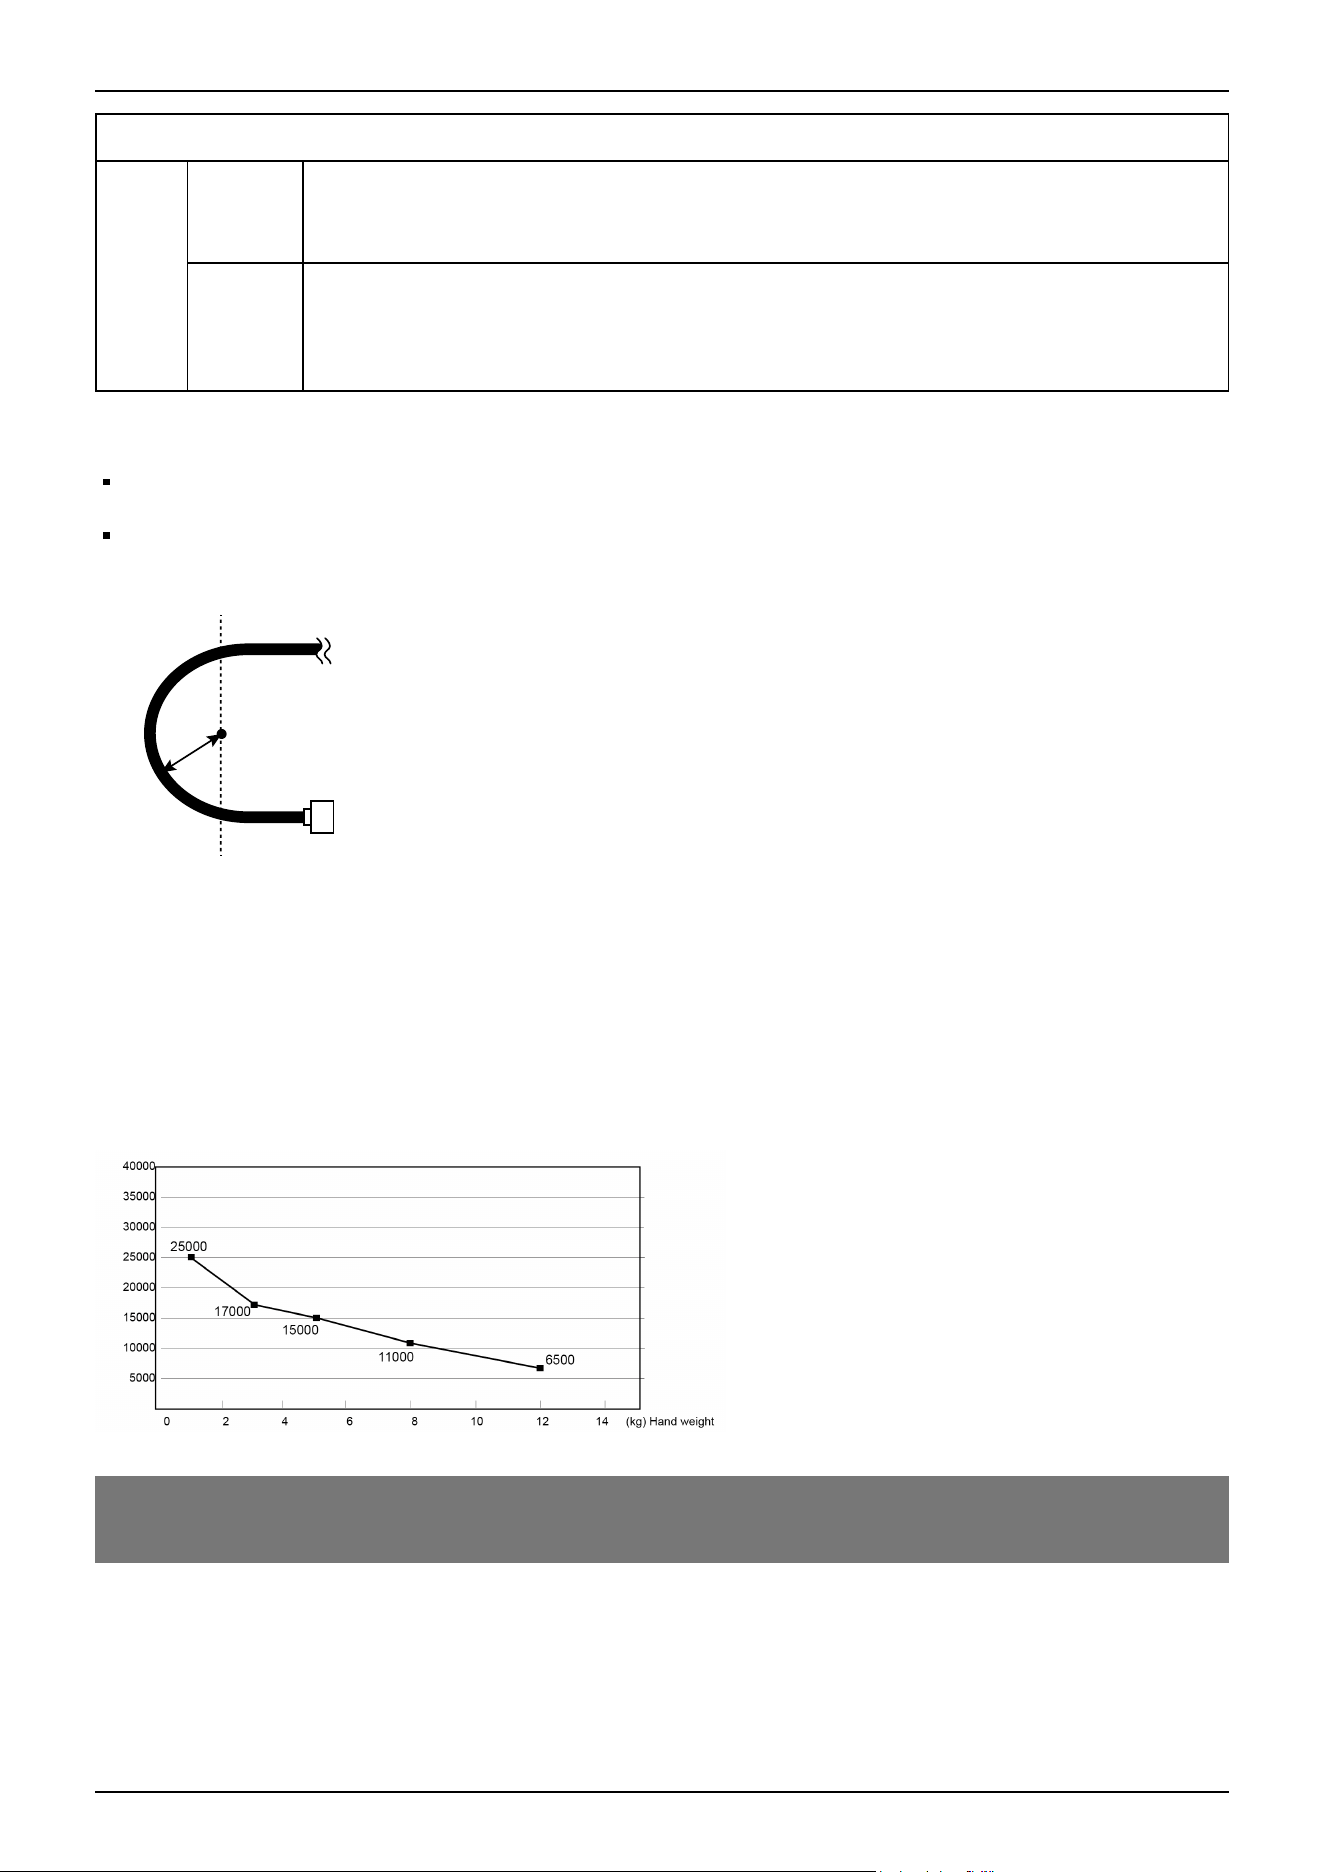
Protection Class
IP67
Dust
protection
level: 6
A testing rod which is 1.0 mm or longer cannot touch dangerous areas inside of the Manipulator.
Totally protected against dust.
Water
protection
level: 7
Water cannot enter the Manipulator when the Manipulator is immersed in water for 30 minutes under
the condition that the highest point of the Manipulator is located 0.15 m below the surface of the
water and the lowest point is located 1 m below the surface of the water. (The Manipulator is stopped
during the test.)
*12: Note the following points when wiring the movable M/C cable.
Install the cable not to apply a load to the connector.
Bend the cable at the minimum bending radius of the movable part or more. The bending radius (a) and dimensions are
shown in the figure below.
*13: The Accel setting of "100" is the optimum setting that balances acceleration/deceleration and vibration during positioning.
Although values larger than 100 can be set to Accel, it is recommended to minimize the use of large values to necessary
motions since operating the Manipulator continuously with the large Accel setting may shorten the product life remarkably.
*14: Maximum AccelS setting value varies depending on the load. For details, refer to the following figure. Setting the value
which exceeds the maximum AccelS causes an error. Check the setting value.
Maximum AccelS setting value
5.2 Appendix B: Stopping Time and Stopping Distance at Emergency
Stop
The stopping time and stopping distance at an emergency stop are shown in the graphs for each model.
The stopping time is the length of time corresponding to the "Stopping time" in the figure below. Be sure to confirm that a safe
environment is provided where the robot will be installed and operated.
M/C cable
Connector
a
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
162
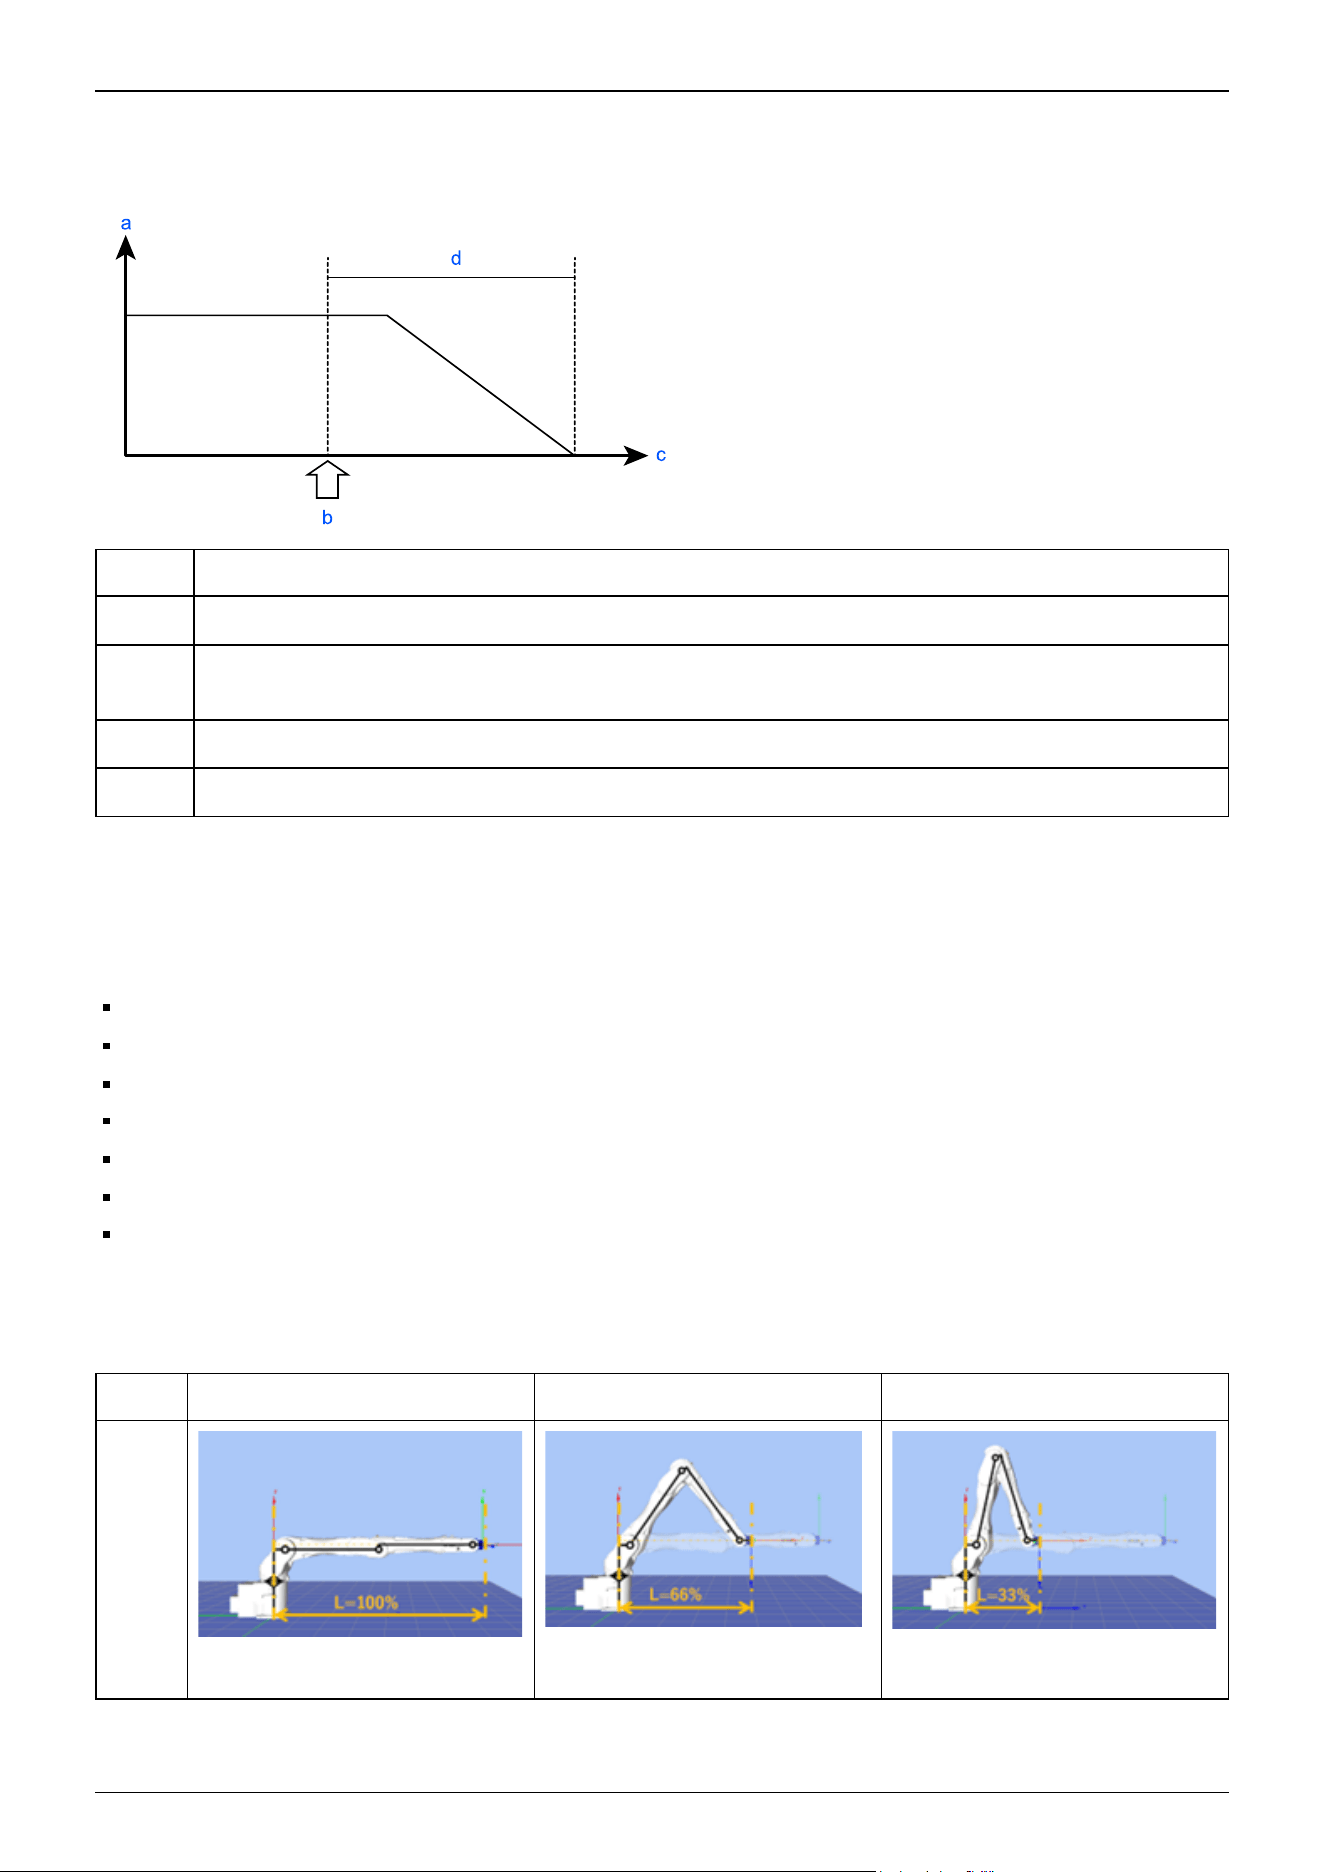
For models equipped with a safety board such as RC800-A, the stopping time and stopping distance when using the Safety
Limited Speed (SLS), Safety Limited Position (SLP), and Soft Axis Limiting are equivalent to those of the emergency stop.
Symbol Description
a Motor speed
b
Emergency stop, Maximum Speed of SLS exceeded, monitoring areas and Joint Angle Limit of SLP exceeded,
restricted range of Soft Axis Limiting exceeded
c Time
d Stopping time
Conditions
The stopping time and stopping distance depend on the parameters (setting values) that were set for the robot. These graphs
show the times and distances for the following parameters.
These conditions are based on the ISO 10218-1:2011 Annex B.
Accel: 100, 100
Speed: 100 %, 66 %, 33 % Settings
Weight: 100 %, 66 %, 33 % of the maximum payload, rated payload
Arm elongation rate: 100 %, 66 %, 33 % *1
Other settings: Default
Motion: Singular axis motion of a Go command
Input timing of the Stop signal: input with maximum speed. In this motion, it is the center of the motion range.
*1 Arm elongation rate
The arm elongation rate L is as shown below: The graphs indicate the results where the stopping time and the stopping distance
in the longest among the arm elongation rates.
Axis L=100% L=66% L=33%
J1
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
163
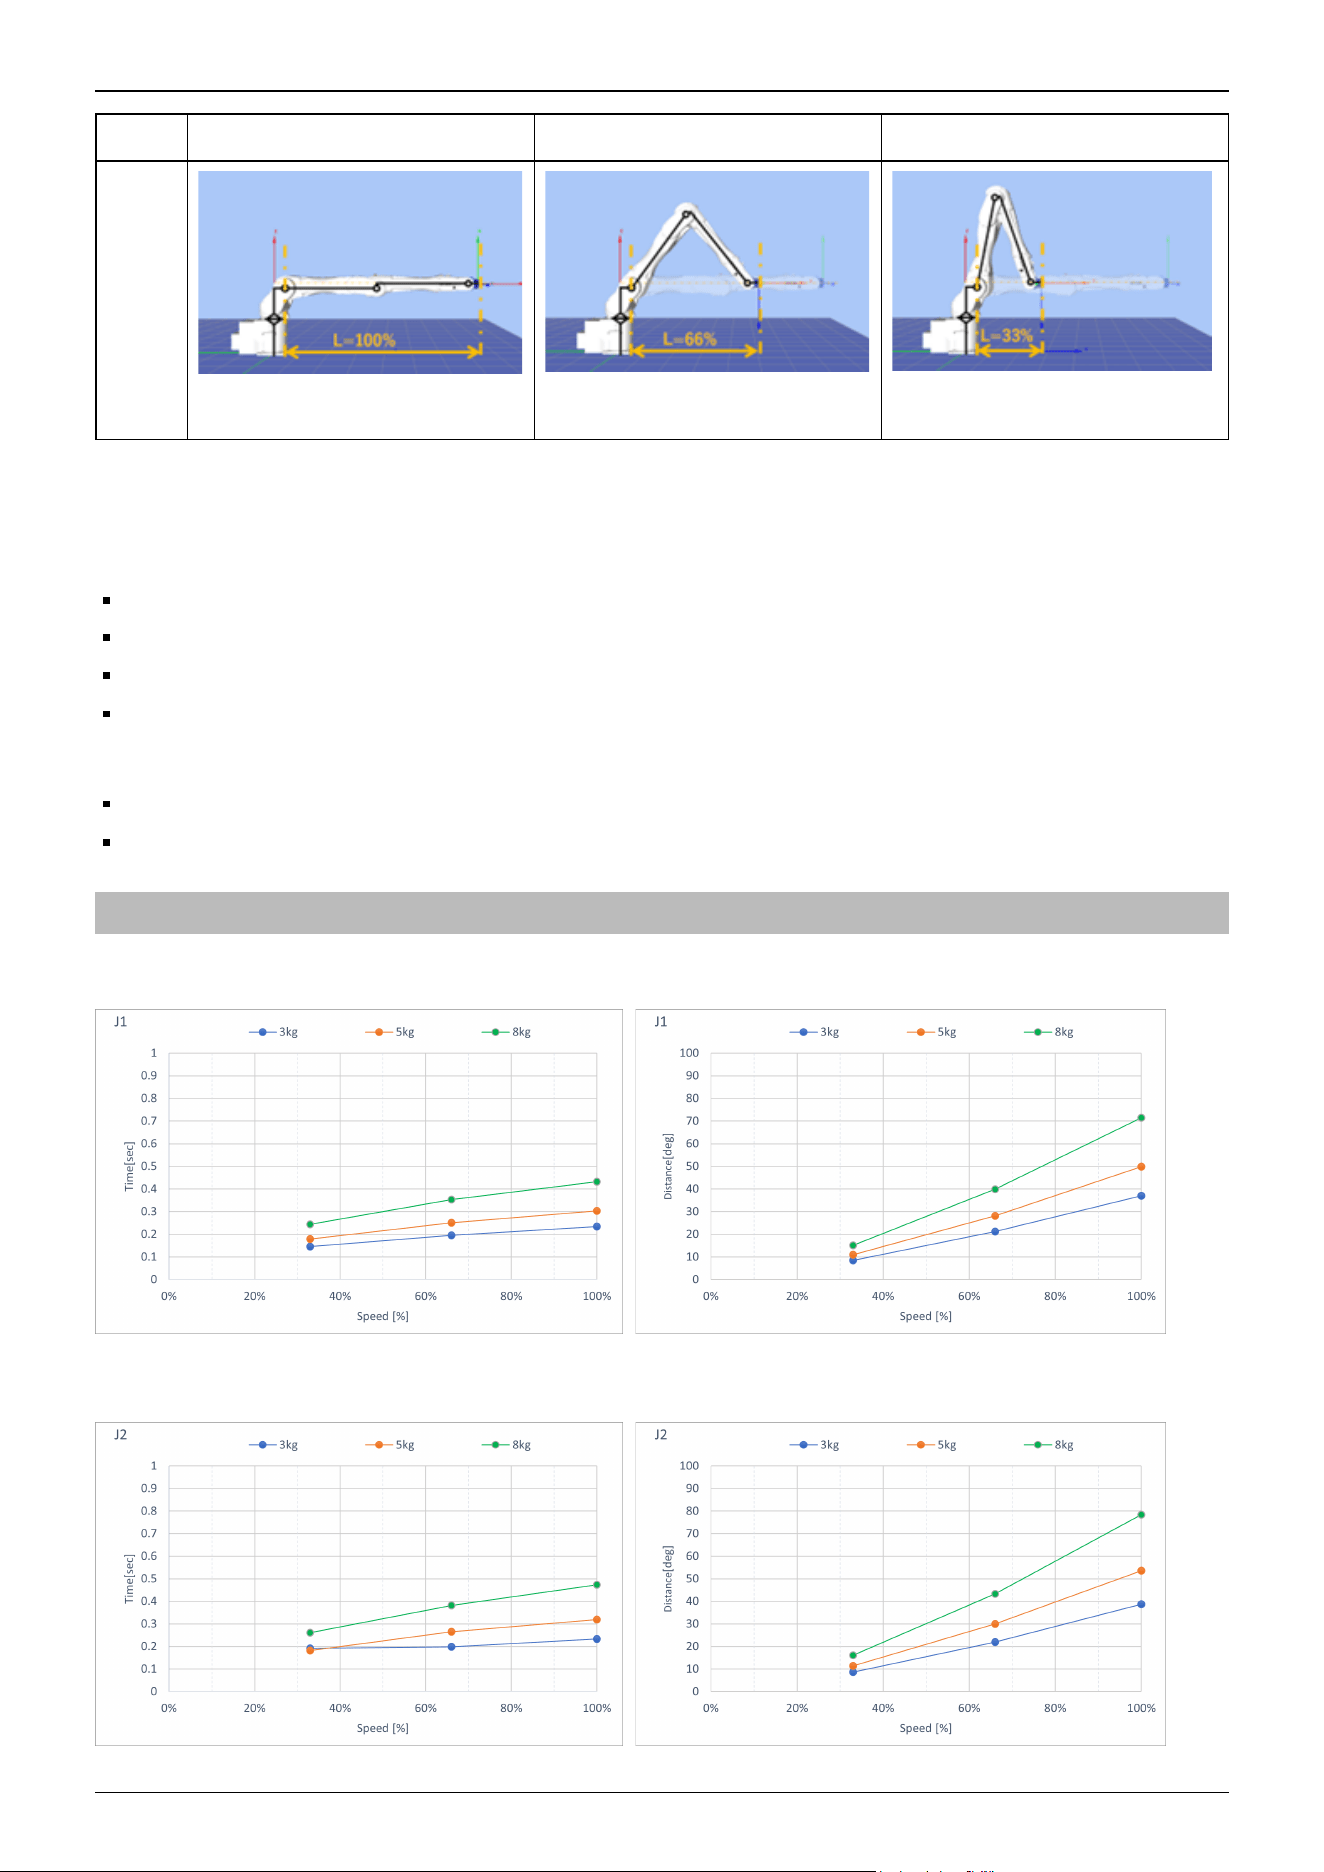
Axis L=100% L=66% L=33%
J2
Explanation of legend
The graphs are displayed for each Weight setting value (at 100%, approx. 66%, and approx. 33% of the maximum payload, and
at the rated payload).
Horizontal axis: Arm speed (Speed setting)
Vertical axis: Stopping time and stopping distance at each arm speed
Time (sec): Stopping time (sec)
Distance (deg): stopping distance (degree)
When single failures are taken into account, the following adjustments are used.
Stopping distance and angle: Each axis reaches the mechanical stop
Stopping time: Add 500 ms
5.2.1 C8-C Stopping Time and Stopping Distance at Emergency Stop
C8-C901***: J1 (Table top mounting, Ceiling mounting)
C8-C901***: J2 (Table top mounting, Ceiling mounting)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
164
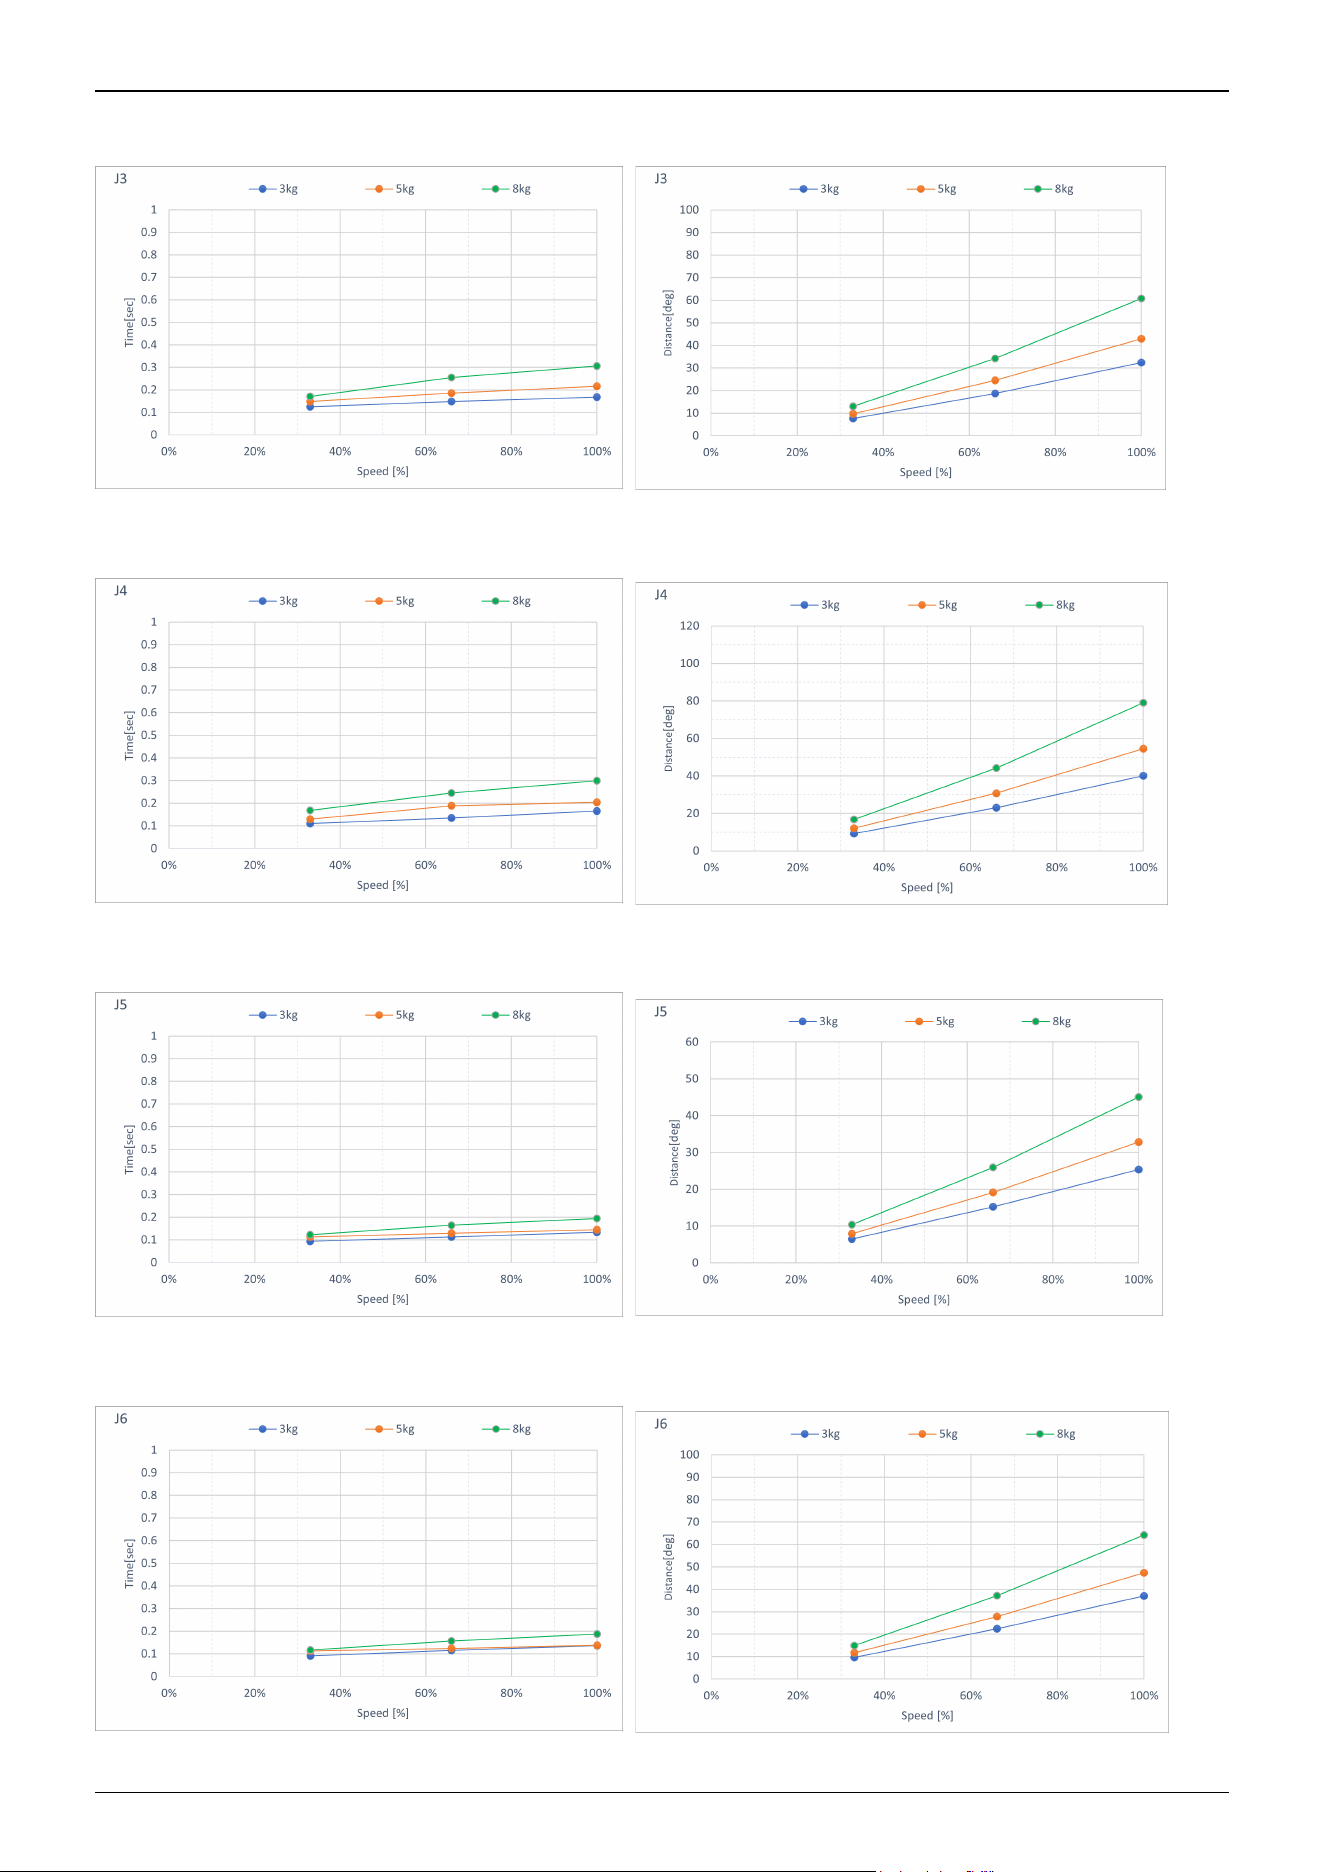
C8-C901***: J3 (Table top mounting, Ceiling mounting)
C8-C901***: J4 (Table top mounting, Ceiling mounting)
C8-C901***: J5 (Table top mounting, Ceiling mounting)
C8-C901***: J6 (Table top mounting, Ceiling mounting)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
165
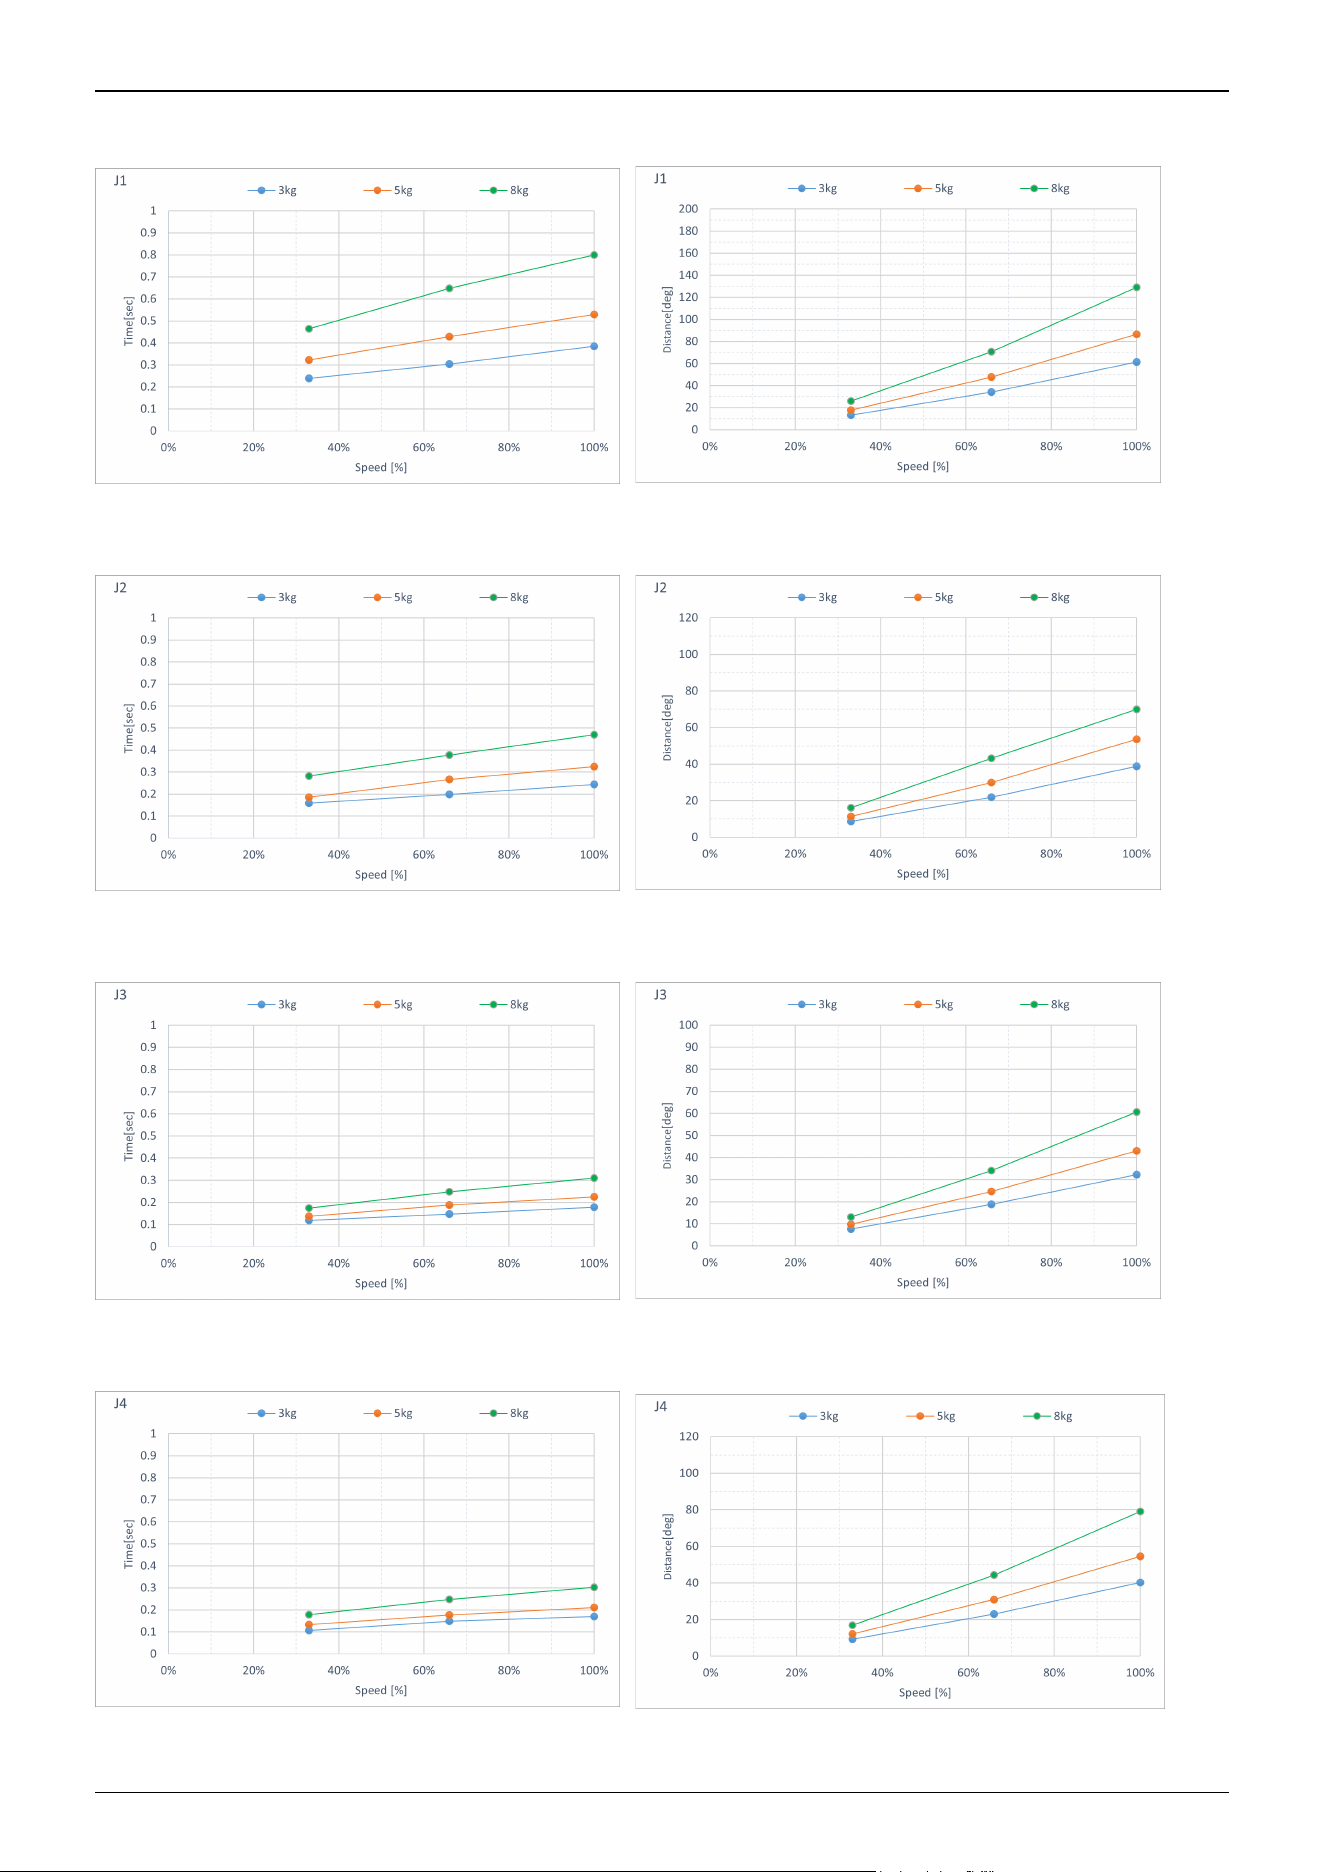
C8-C901***: J1 (Wall mounting)
C8-C901***: J2 (Wall mounting)
C8-C901***: J3 (Wall mounting)
C8-C901***: J4 (Wall mounting)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
166
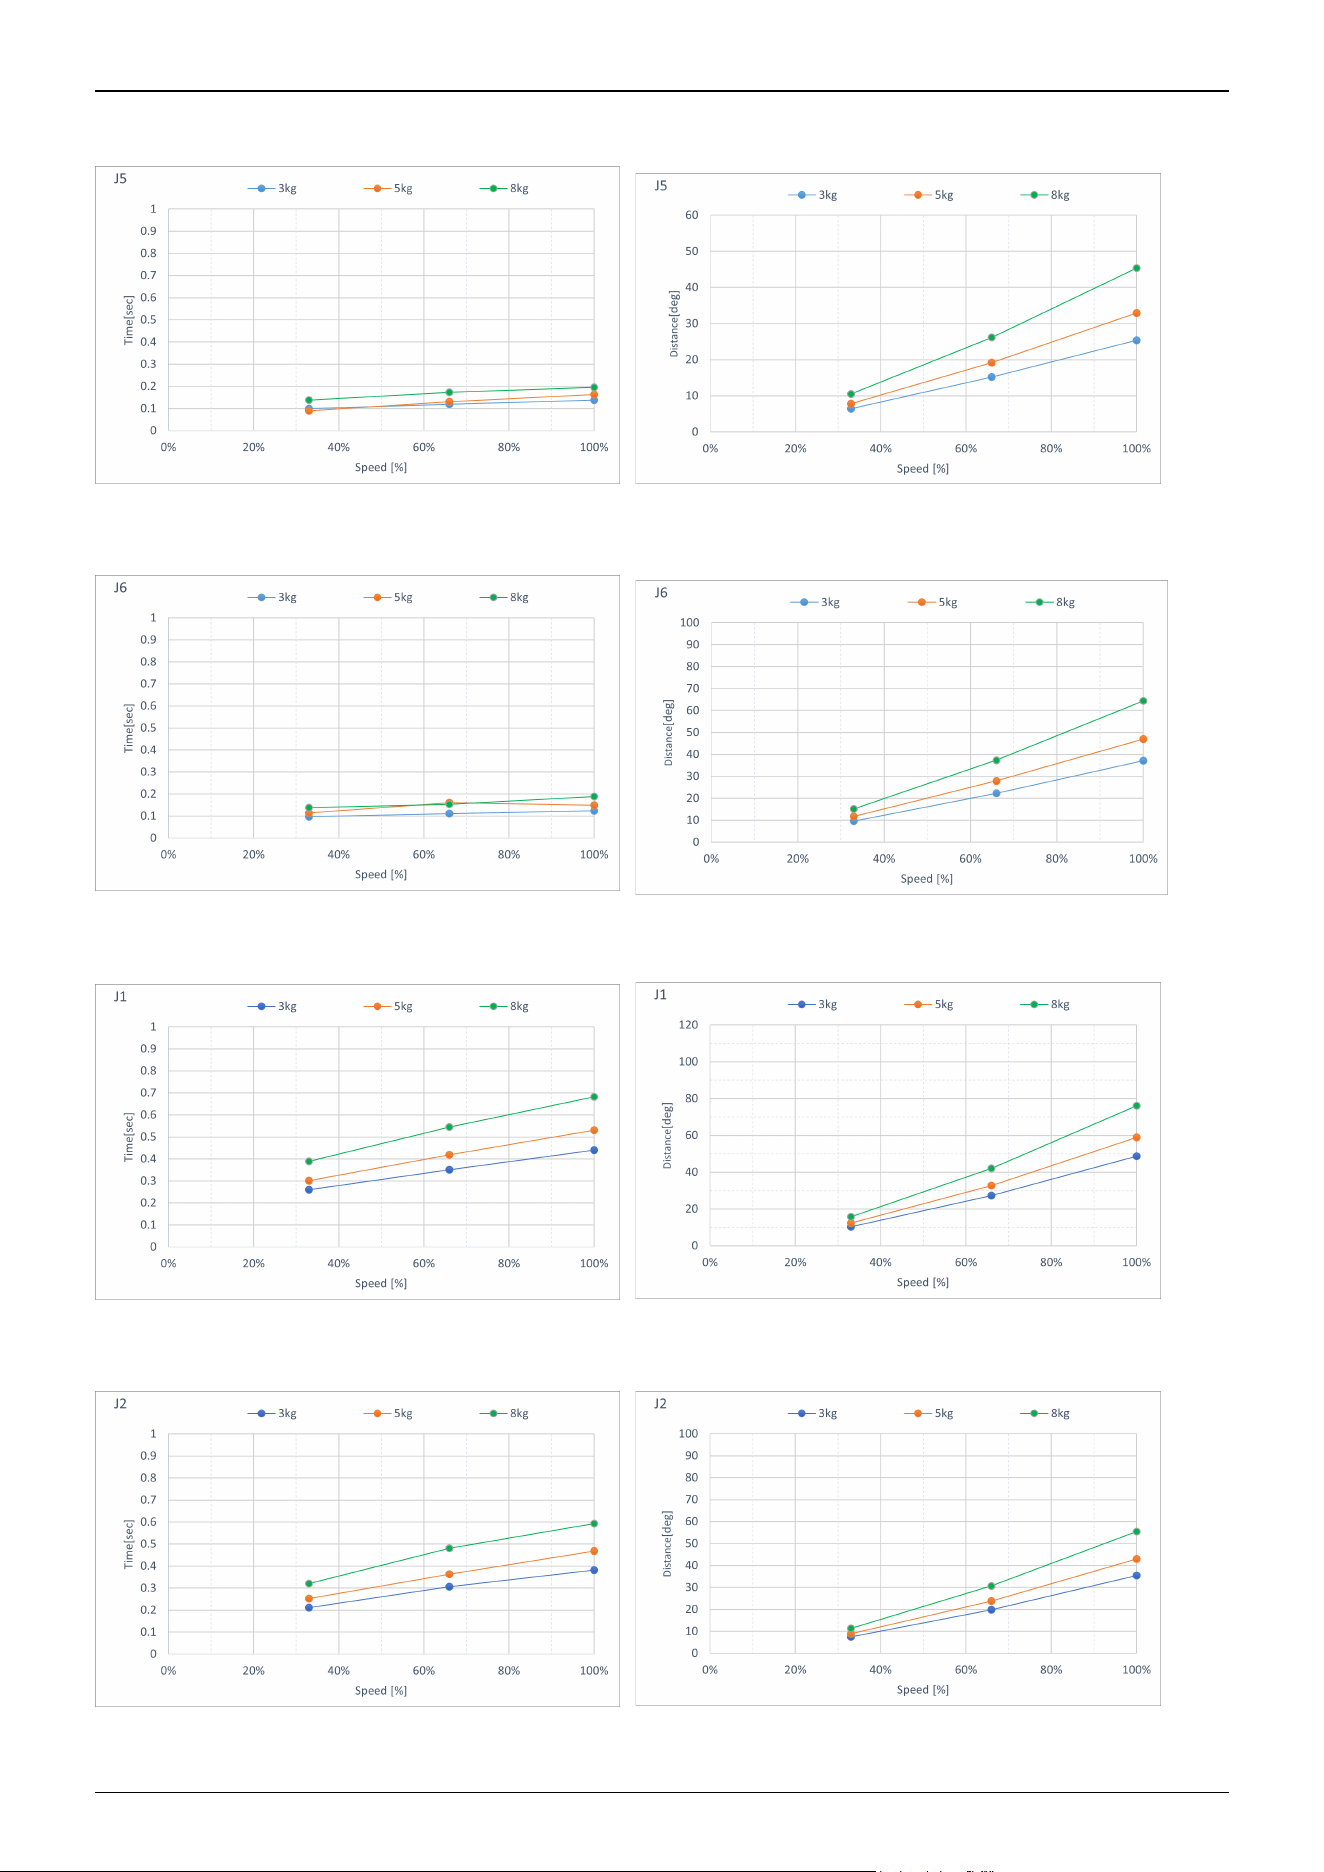
C8-C901***: J5 (Wall mounting)
C8-C901***: J6 (Wall mounting)
C8-C1401***: J1 (Table top mounting, Ceiling mounting)
C8-C1401***: J2 (Table top mounting, Ceiling mounting)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
167
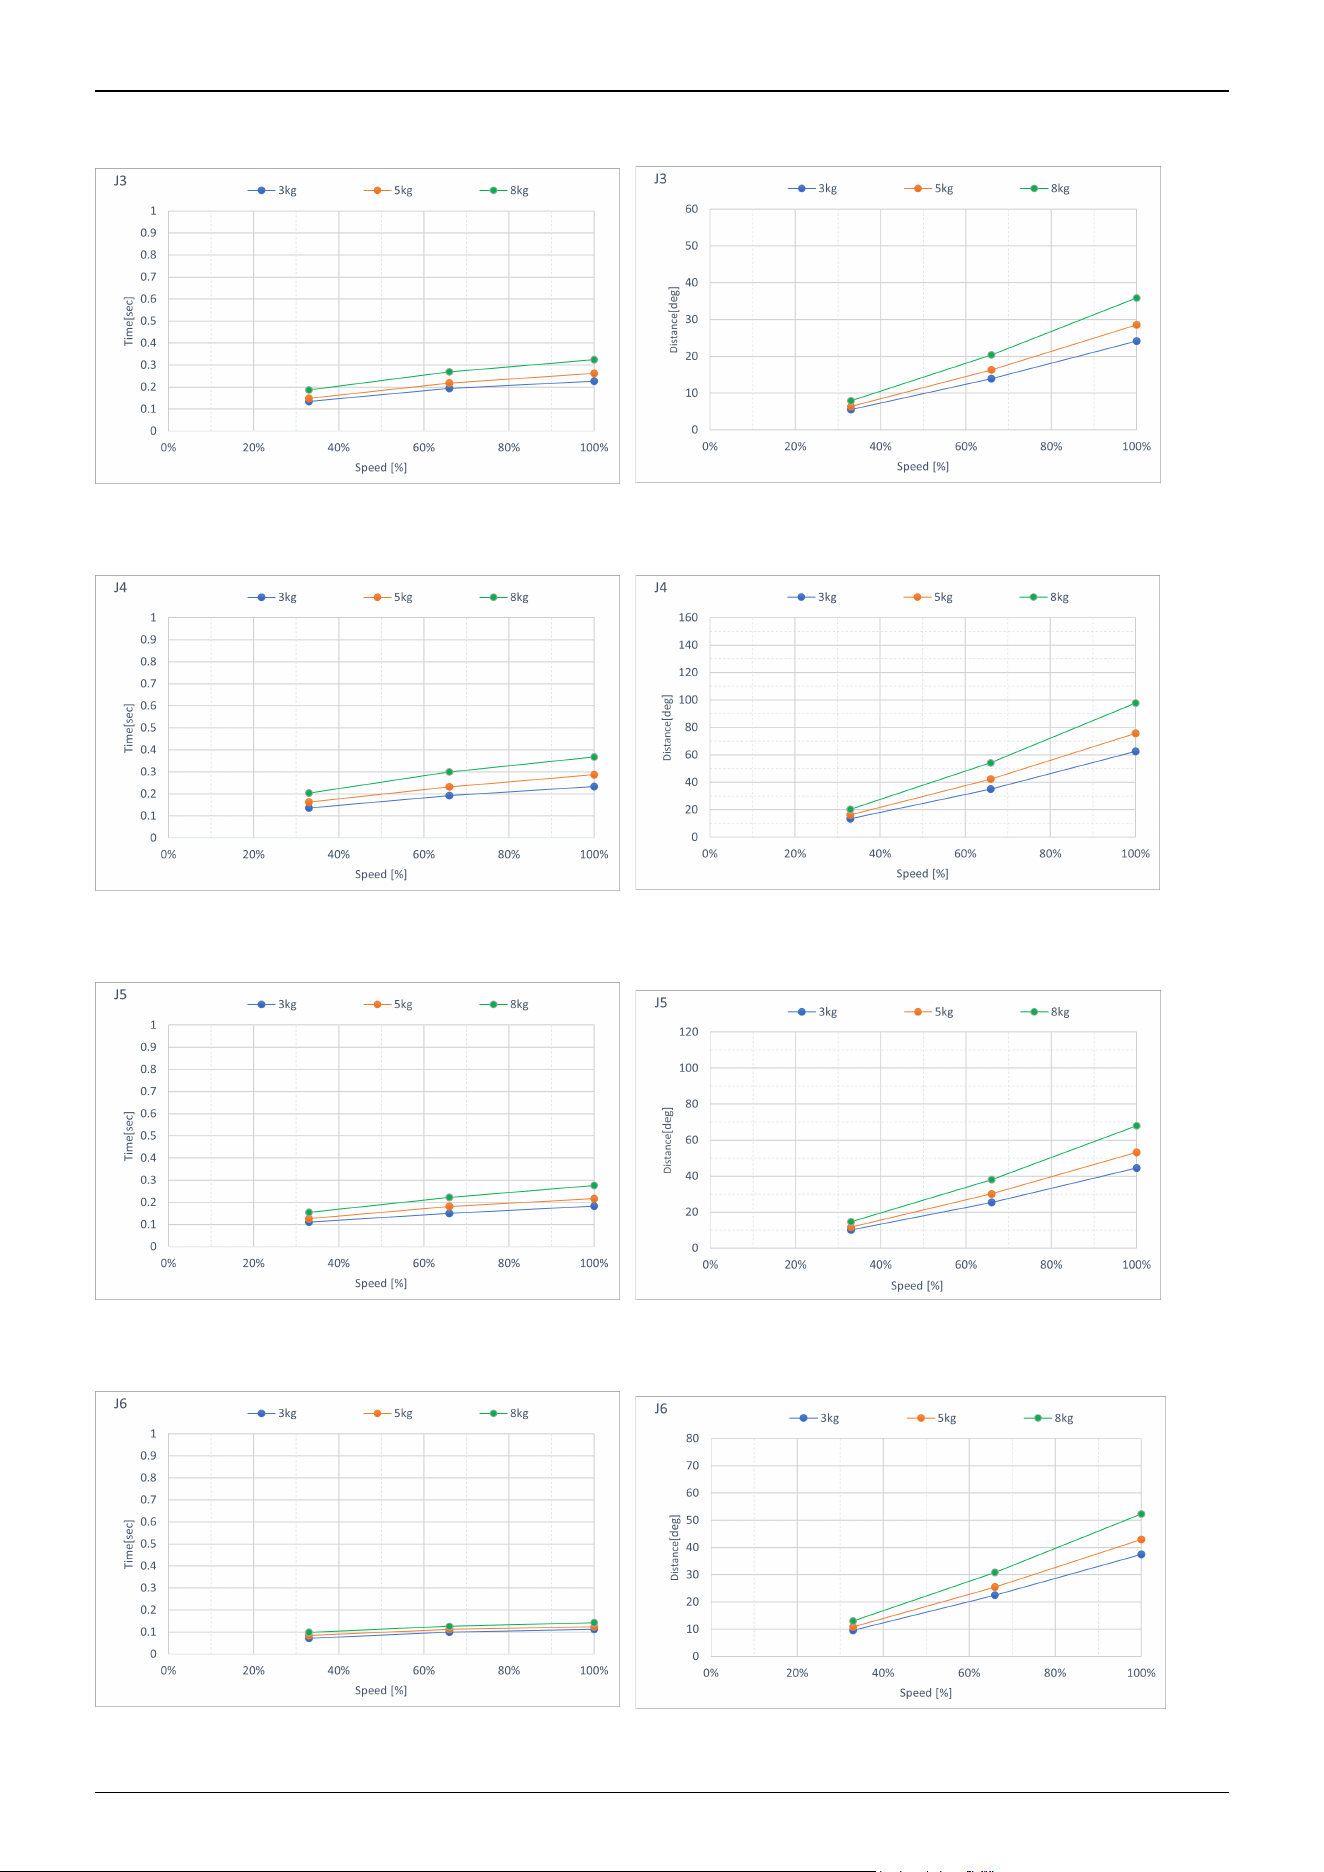
C8-C1401***: J3 (Table top mounting, Ceiling mounting)
C8-C1401***: J4 (Table top mounting, Ceiling mounting)
C8-C1401***: J5 (Table top mounting, Ceiling mounting)
C8-C1401***: J6 (Table top mounting, Ceiling mounting)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
168
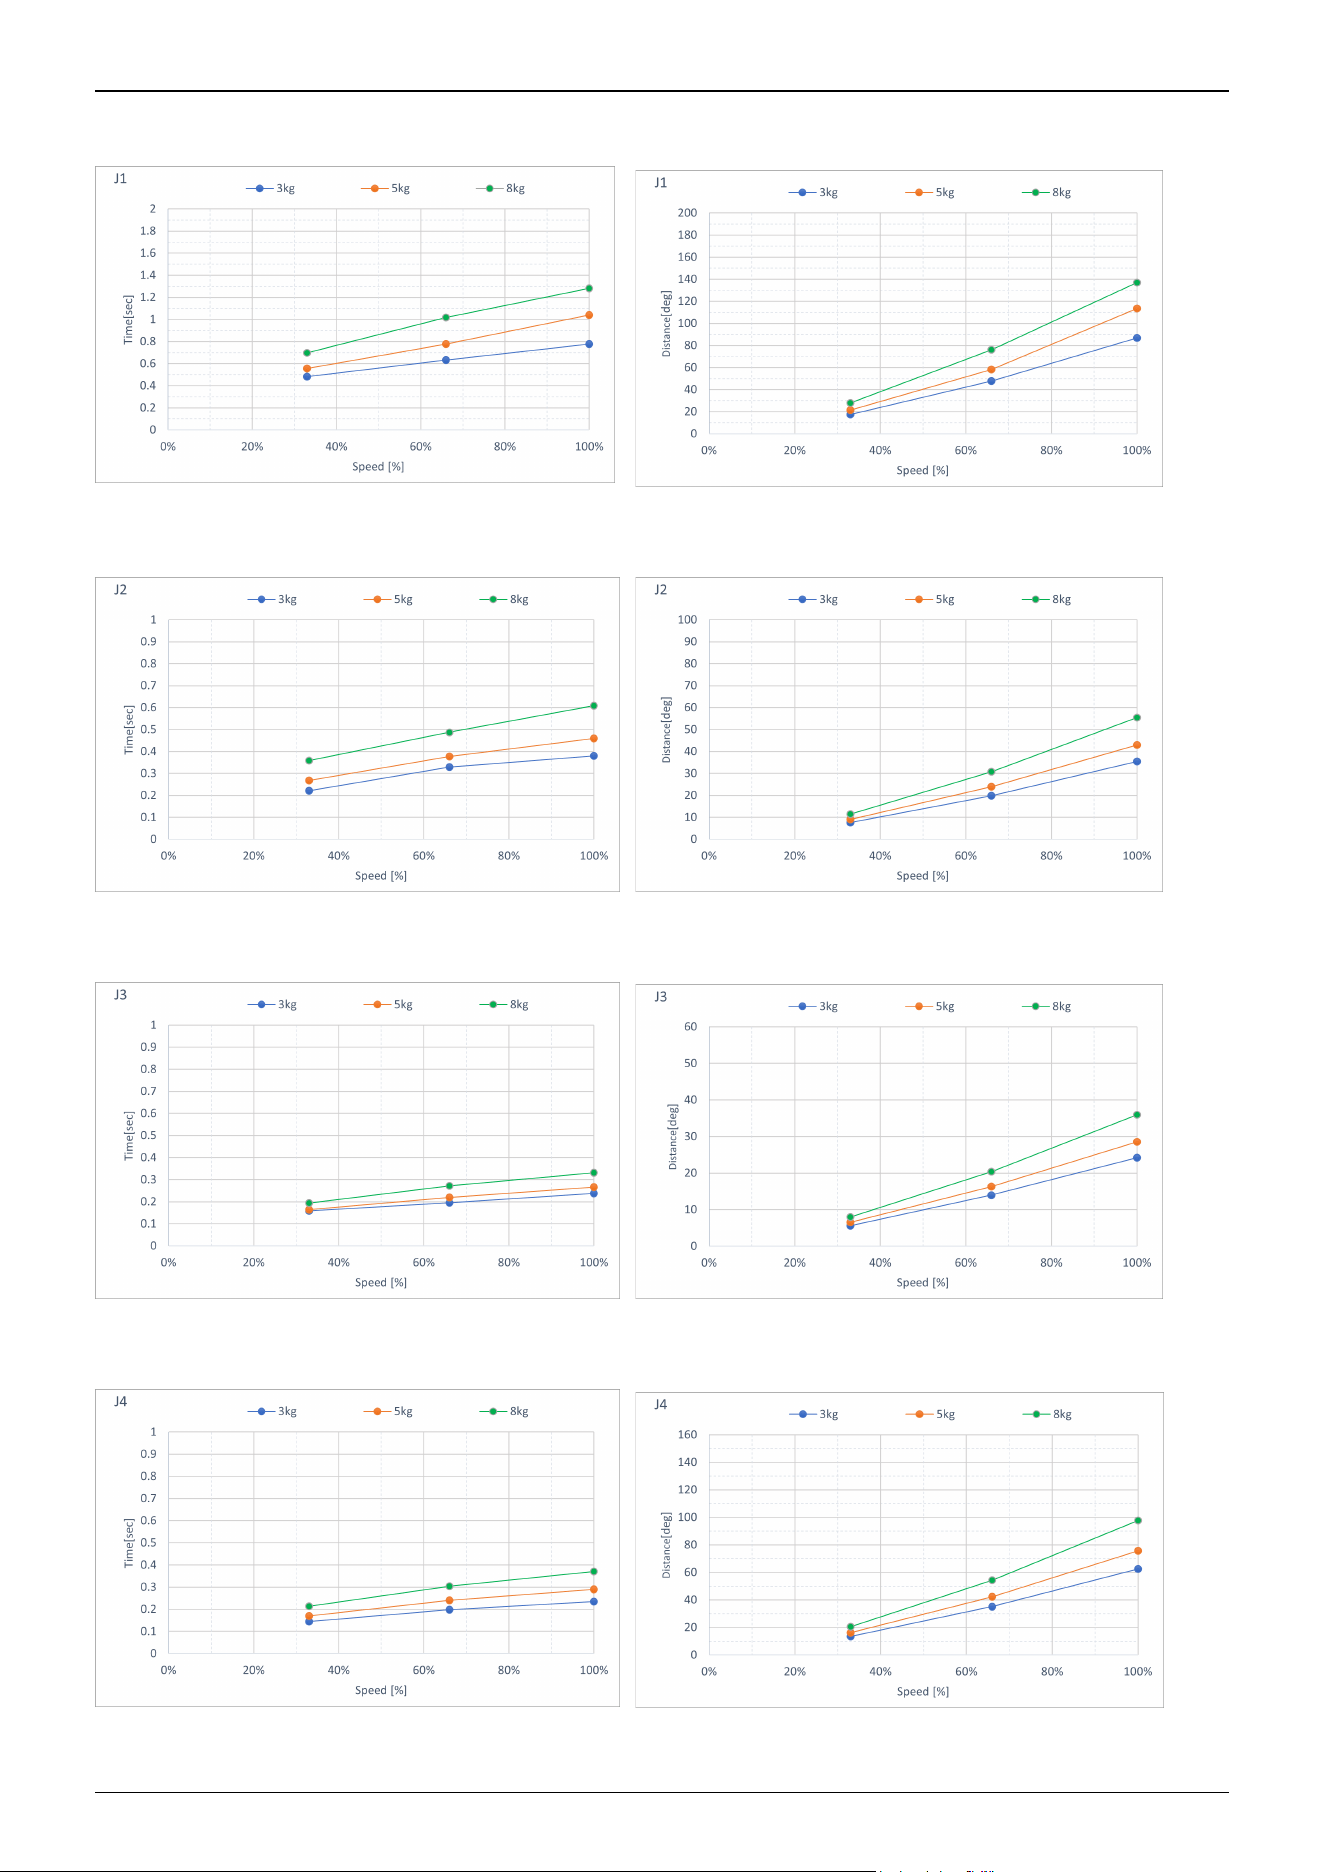
C8-C1401***: J1 (Wall mounting)
C8-C1401***: J2 (Wall mounting)
C8-C1401***: J3 (Wall mounting)
C8-C1401***: J4 (Wall mounting)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
169
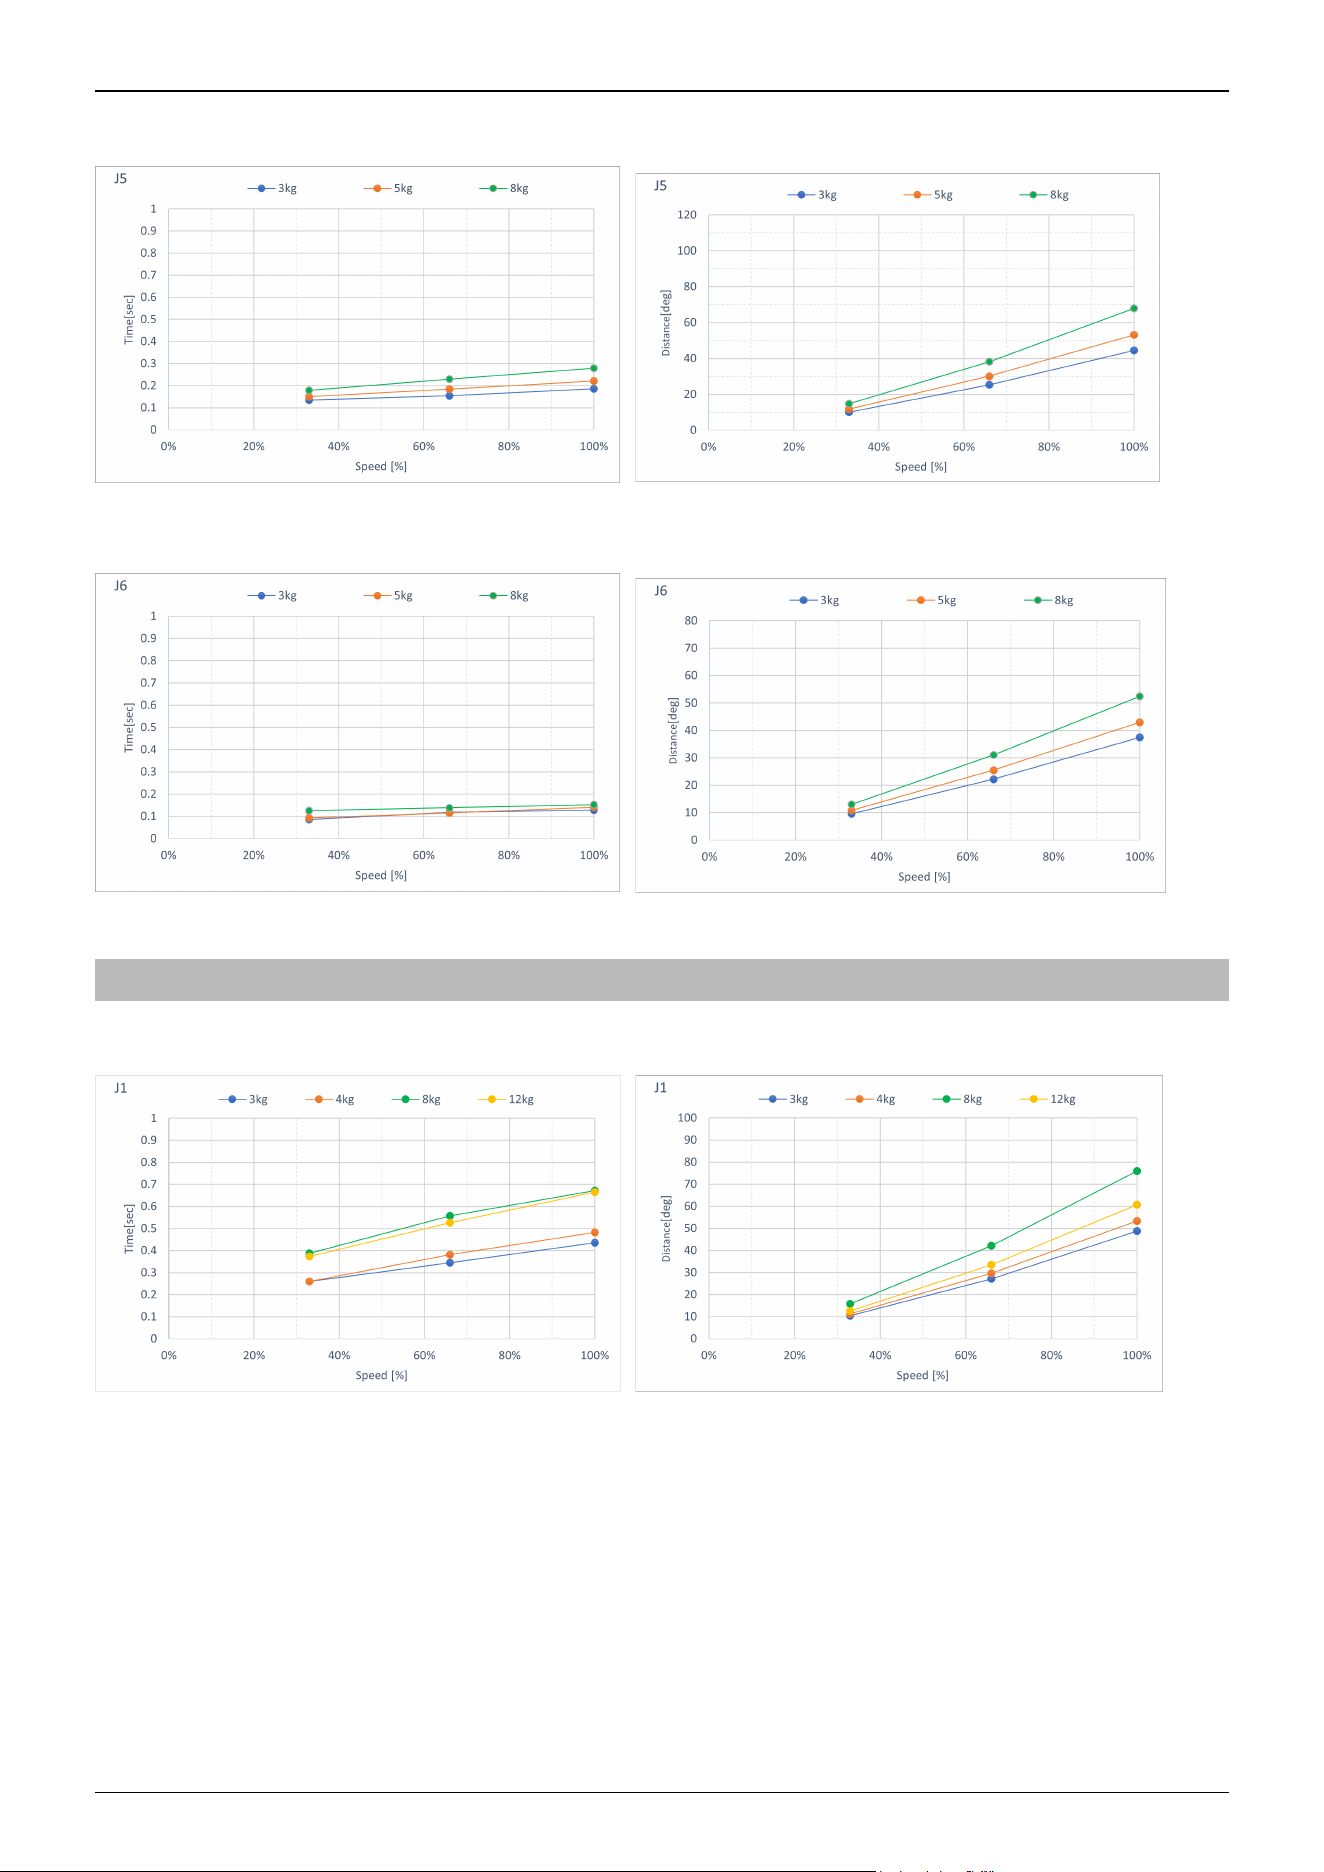
C8-C1401***: J5 (Wall mounting)
C8-C1401***: J6 (Wall mounting)
5.2.2 C12-C Stopping Time and Stopping Distance at Emergency Stop
C12-C1401**: J1 (Table top mounting)
C12-C1401**: J2 (Table top mounting)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
170
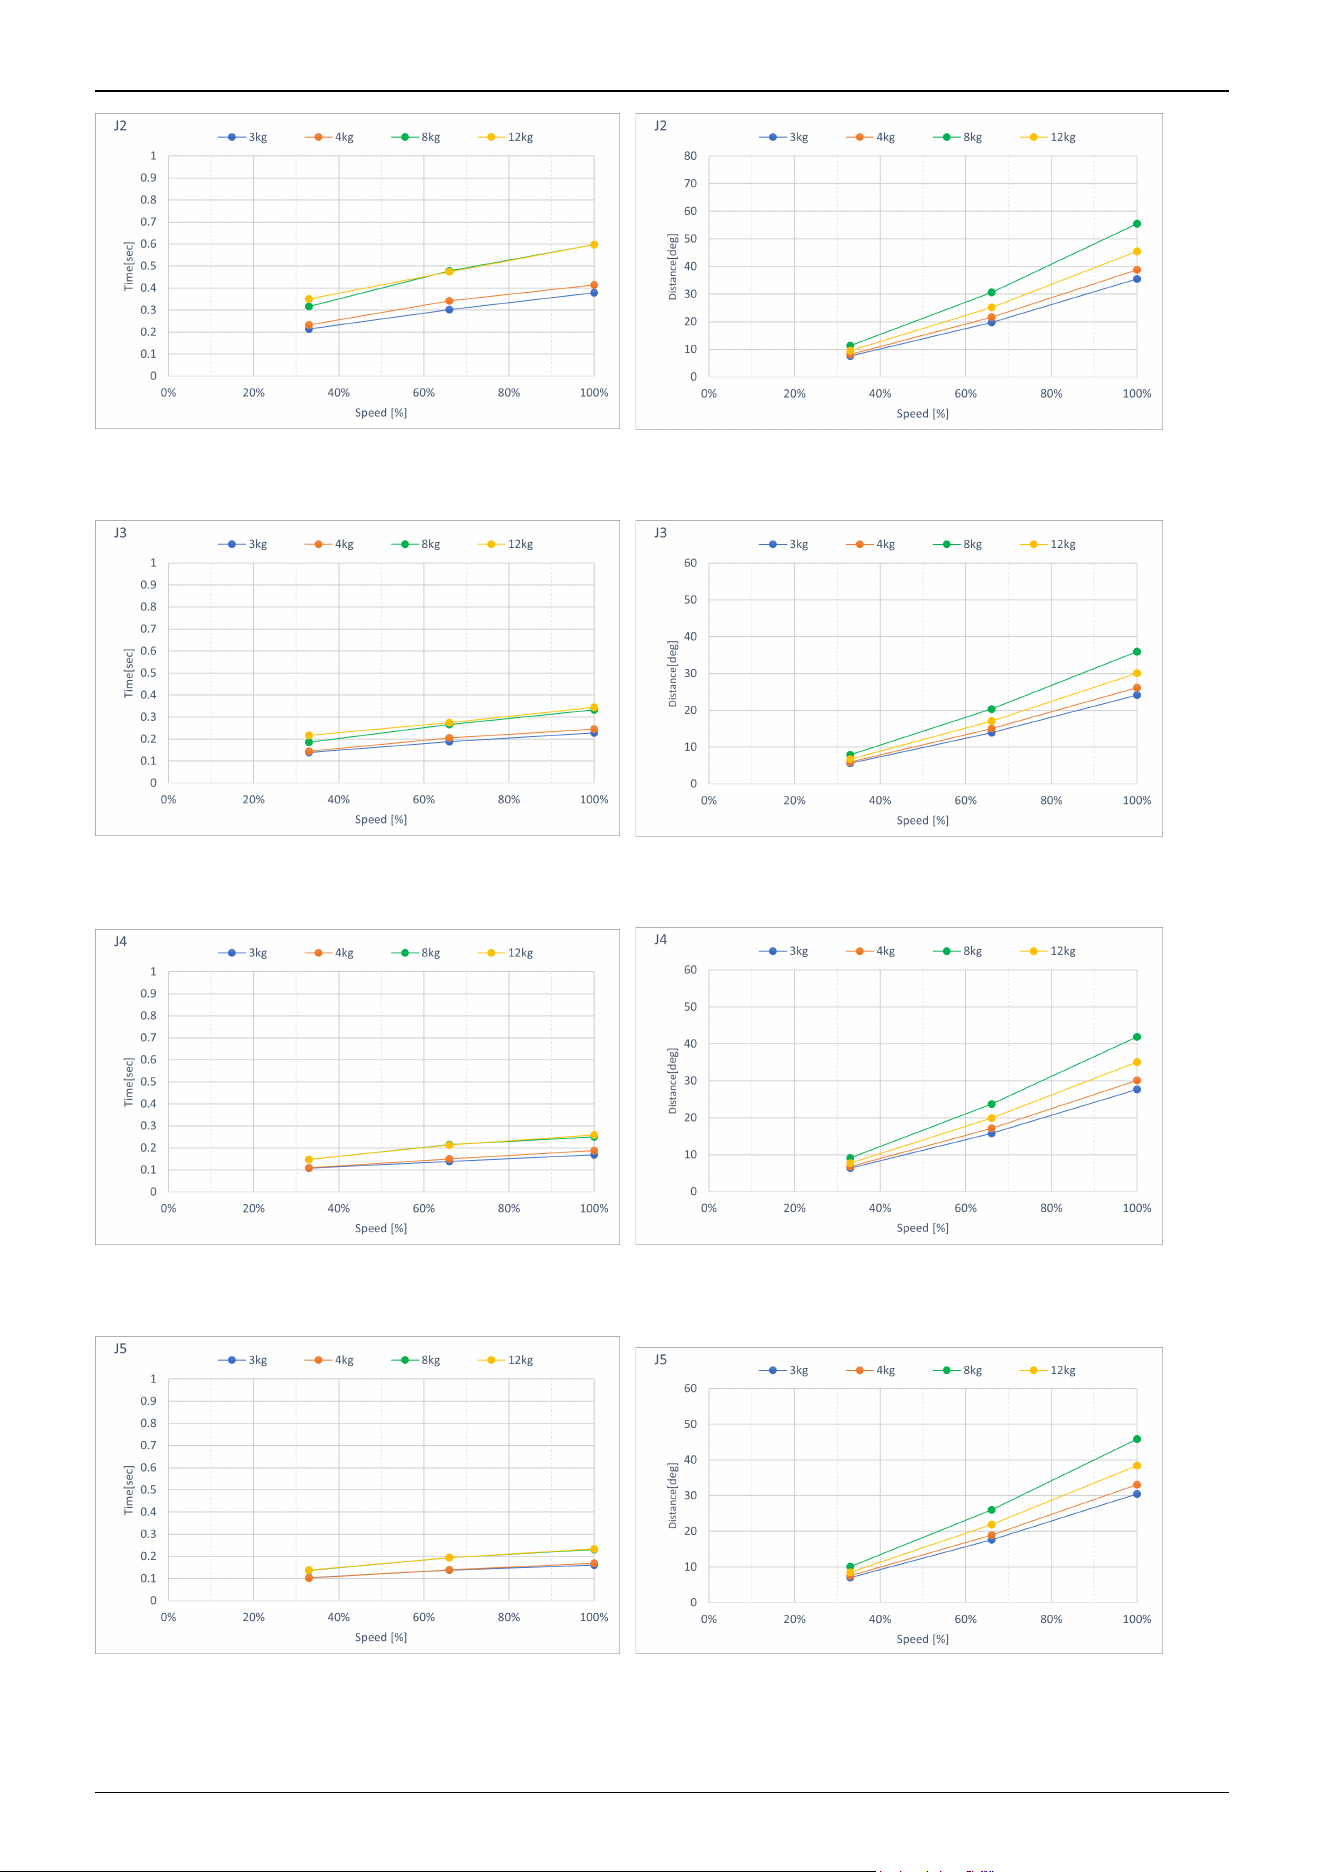
C12-C1401**: J3 (Table top mounting)
C12-C1401**: J4 (Table top mounting)
C12-C1401**: J5 (Table top mounting)
C12-C1401**: J6 (Table top mounting)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
171
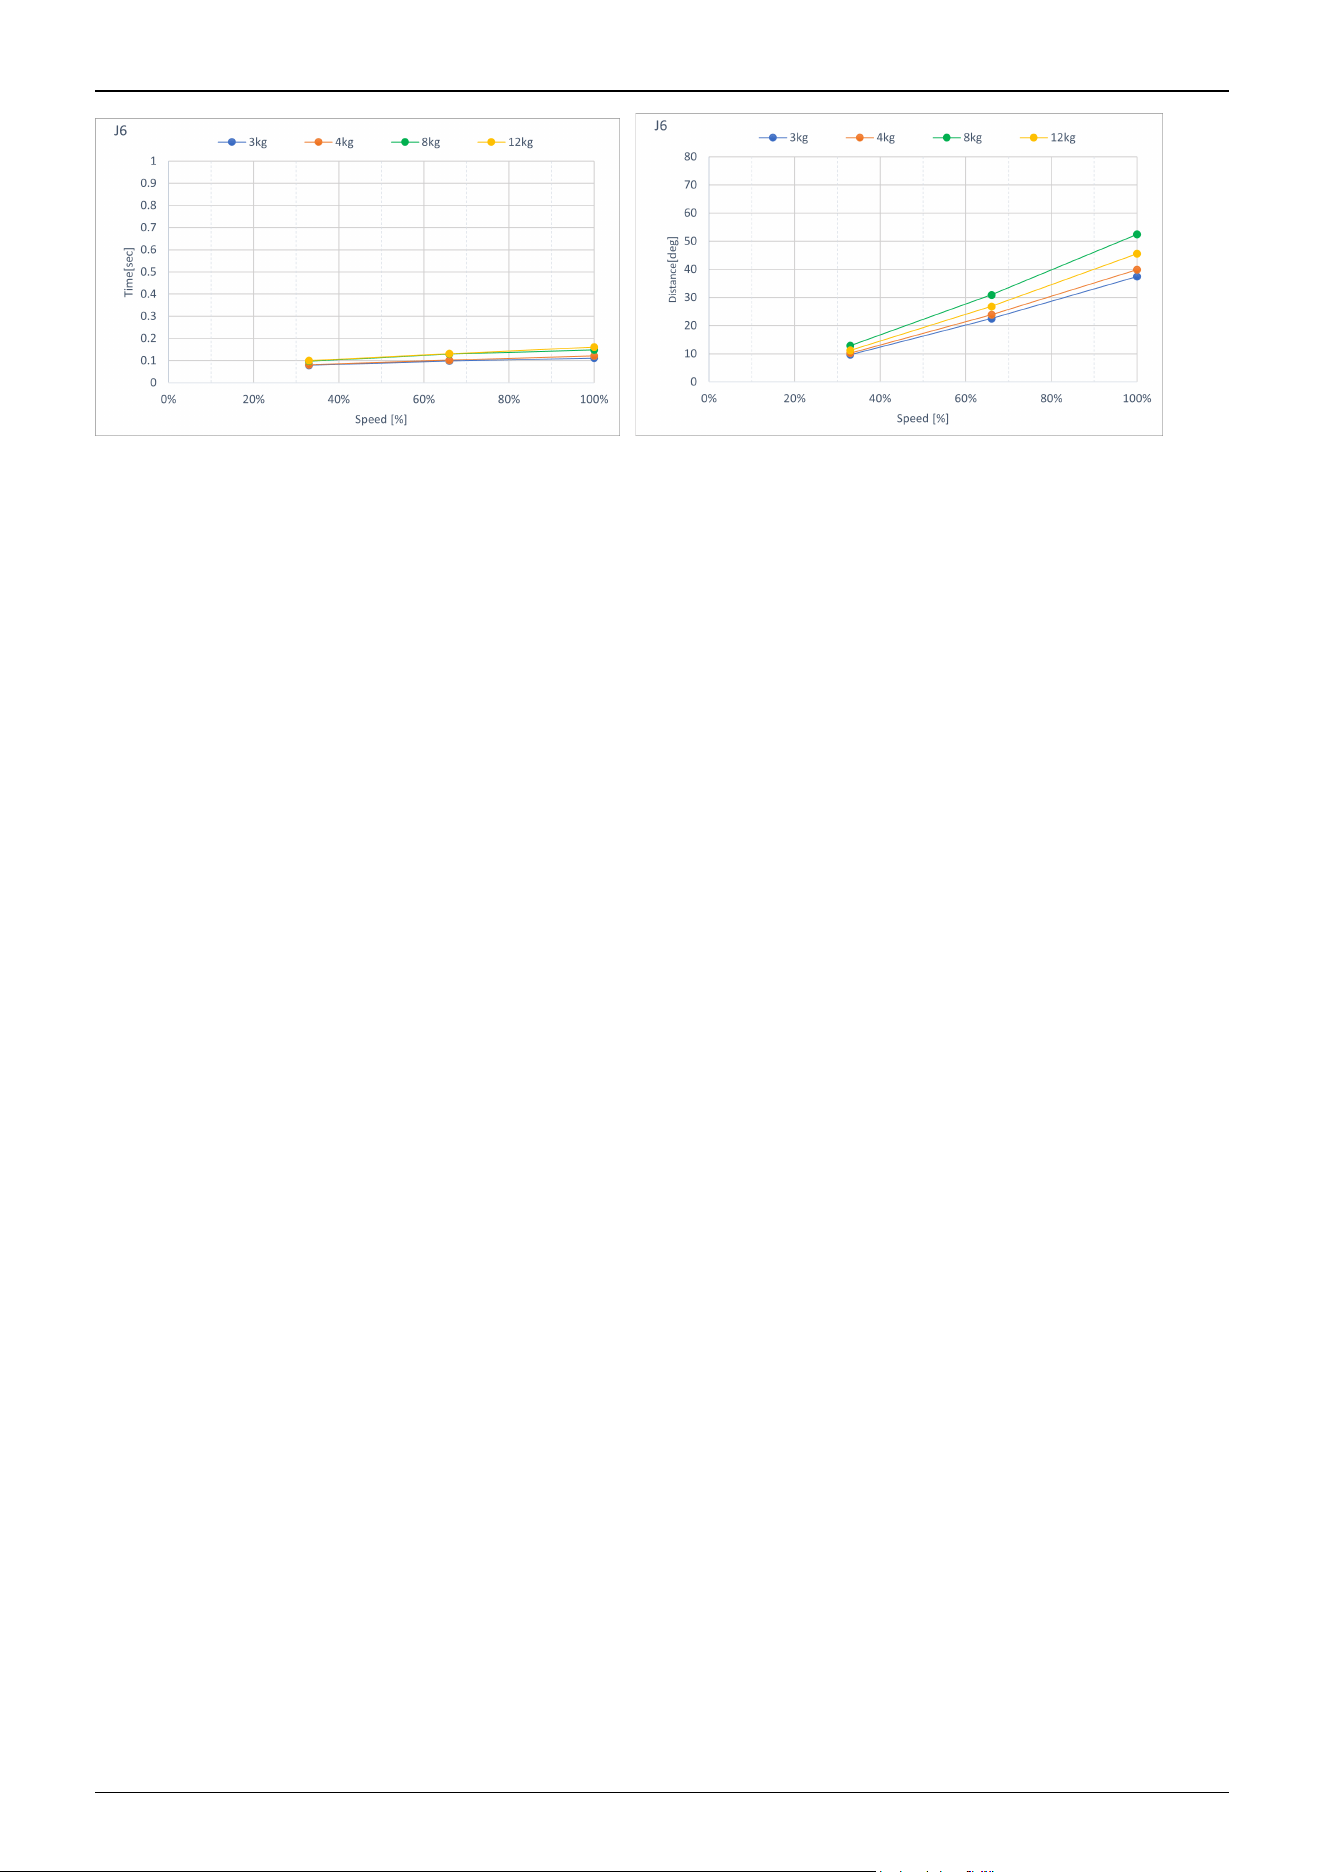
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
172
5.2.3 Supplementary Information regarding the Stopping Time and
Stopping Distance at Emergency Stop
The stopping time and stopping distance described in Appendix B was measured by the motion determined by us based on the
ISO 10218-1.
Therefore, it does not guarantee the maximum value of the stopping time and stopping distance in the customer’s environment.
The stopping time and stopping distance differs depending on the robot’s model, motion, and input timing of the stop signal.
Make sure to always measure the stopping time and stopping distance that matches the customer’s environment.
KEY POINTS
The following are included in the robot’s motion and parameter.
The motion’s starting point, target point, and relay point
Motion commands (Go, Move, Jump commands etc.)
Weight and Inertia Settings
Motion speed, acceleration, deceleration, and one where the motion timing changes
Also, refer to the following description.
C8:
WEIGHT and INERTIA Settings
Safety Information for Auto Acceleration
C12:
WEIGHT and INERTIA Settings
Safety Information for Auto Acceleration
5.2.3.1 How to check the stopping time and stopping distance in the customer’s
environment
Measure the stopping time and stopping distance of the actual motion with the following method.
1. Create a motion program in the customer’s environment.
2. After the motion to check the stopping time and stopping distance starts, input the stop signal at your own timing.
3. Record the time and distance from when the stop signal was input until the robot stopped.
4. Check the maximum stopping time and stopping distance by repeating 1 through 3 mentioned above.
How to input the stop signal: Operate the stop switch manually or input the stop signal with the safety PLC.
How to measure the stopping position: Measure with a tape measure. The angle could also be measured with the Where or
RealPos command.
How to measure the stopping time: Measure with a stop watch. The Tmr function can also be used to measure the stopping
time.
CAUTION
The stopping time and stopping distance changes depending on the timing the stop signal is input.
In order to prevent collision with people or objects, perform a risk assessment based on the maximum stopping
time and stopping distance and perform an equipment design.
Therefore, make sure to measure the maximum value by changing the timing of the stop signal input during the
actual motion and measure repeatedly.
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
173
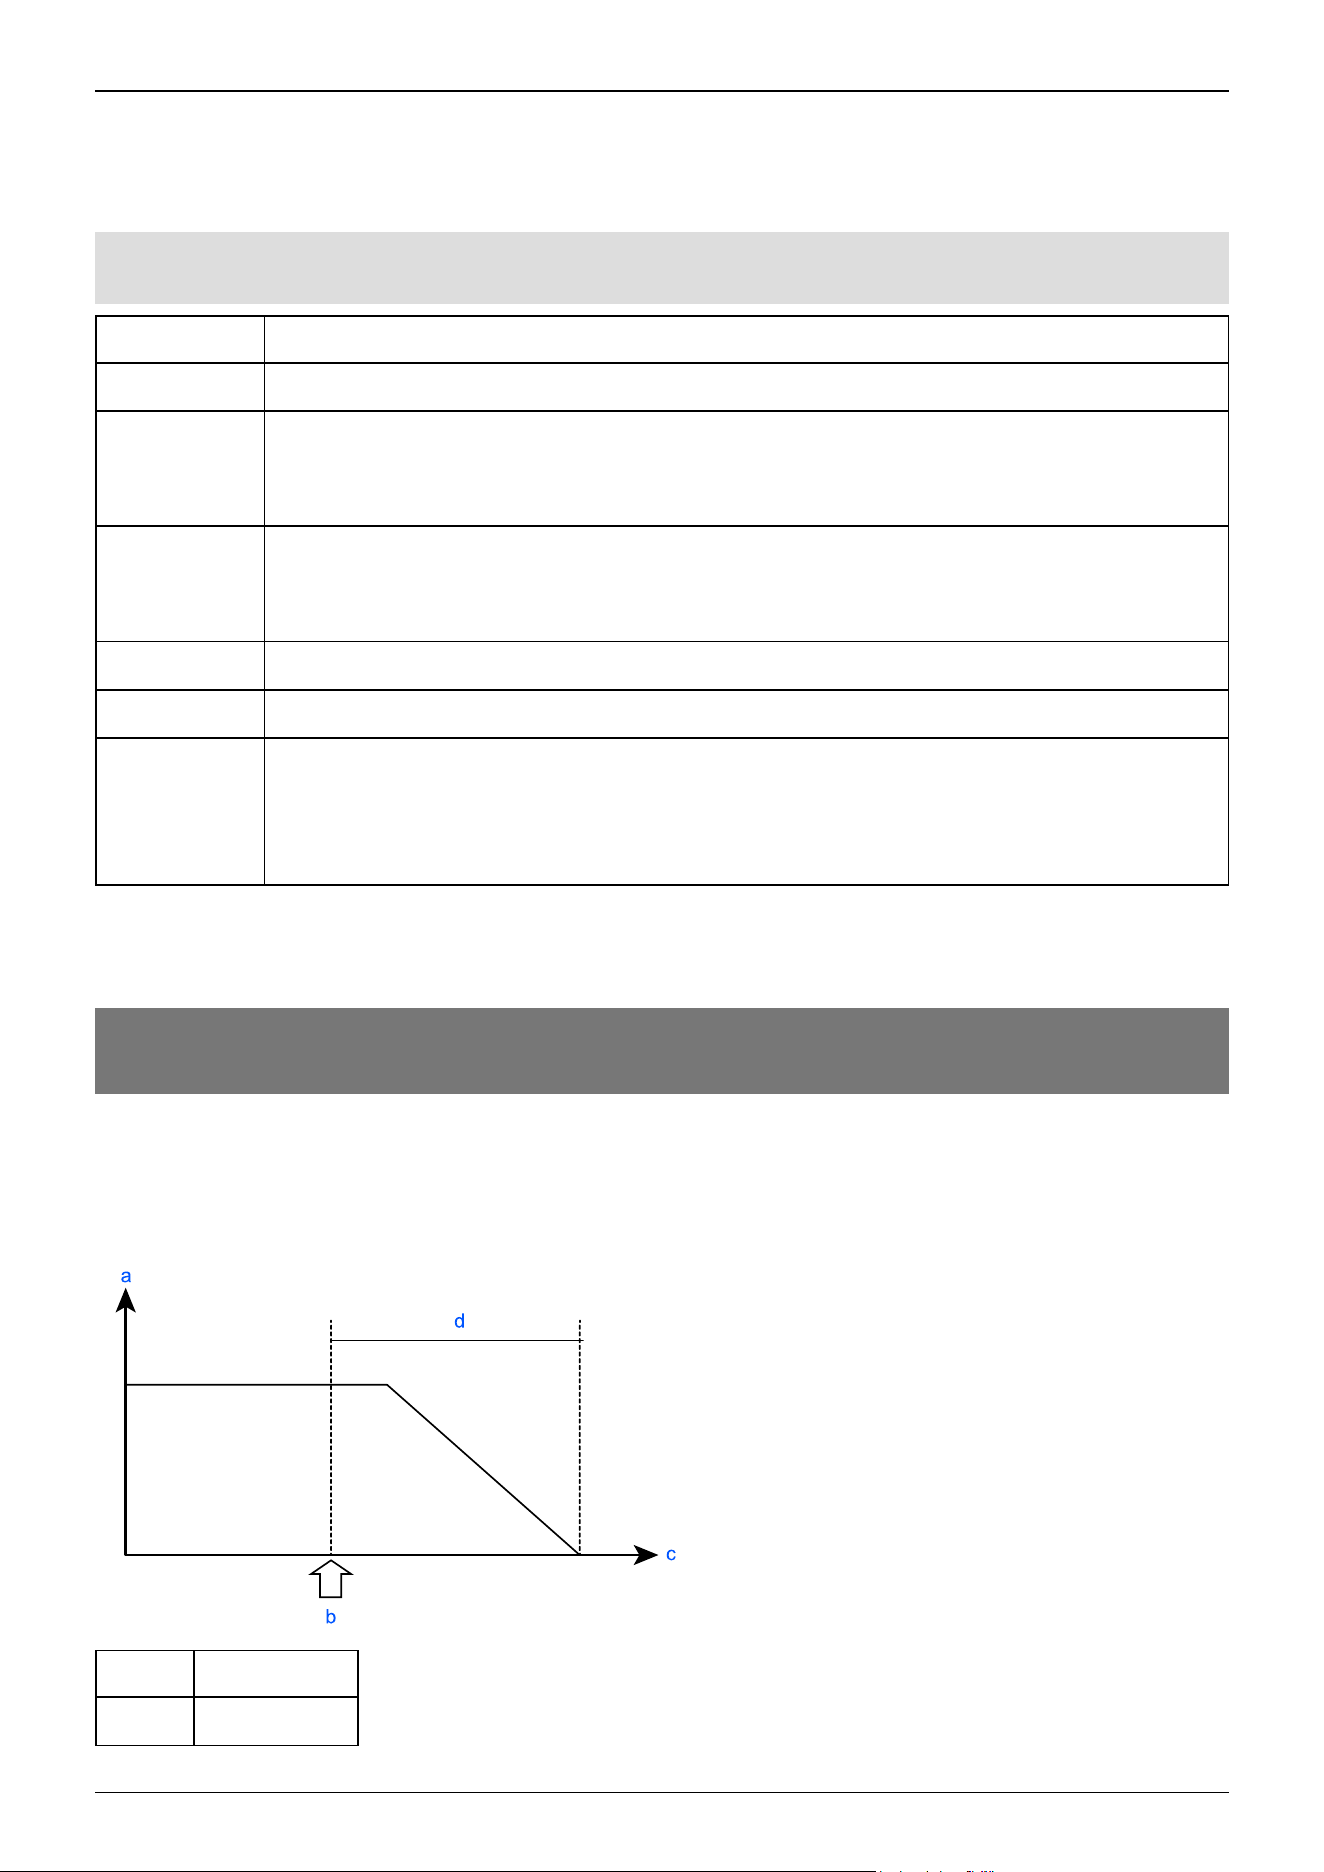
To shorten the stopping time and stopping distance, use the Safety Limited Speed (SLS) and limit the maximum speed.
For details on the safety limited speed, refer to the following manual.
“Safety Function Manual“
5.2.3.2 Commands that can be useful when measuring stopping time and
stopping distance
Commands Functions
Where Returns the data of the robot’s current position
RealPos
Returns the current position of the specified robot
Unlike the motion target position of the CurPos, this obtains the position of the actual robot from the
encoder in real time.
PAgl
Returns by calculating the Joint position from the specified coordinate value.
P1 = RealPos 'Obtain the current position
Joint1 = PAgl (P1, 1) ‘ Request the J1 angle from the current position
SF_RealSpeedS Display the current speed from the limited speed position in mm/s.
Tmr The Tmr function returns the elapsed time from when the timer starts in seconds.
Xqt
Runs the program specified with the function name and complete the task.
The function used to measure the stopping time and stopping distance should be used to run tasks that
were launched by attaching the NoEmgAbort options. You can run a task that does not stop with the
emergency stop and safeguard open.
For more information, refer to the following manual.
"Epson RC+ SPEL+ Language Reference"
5.3 Appendix C: Stopping Time and Stopping Distance When
Safeguard is Open
The stopping time and stopping distance when the safeguard is opened are shown in the graphs for each model.
The stopping time is the length of time corresponding to the "Stopping time" in the figure below. Be sure to confirm that a safe
environment is provided where the robot will be installed and operated.
Symbol Description
a Motor speed
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
174
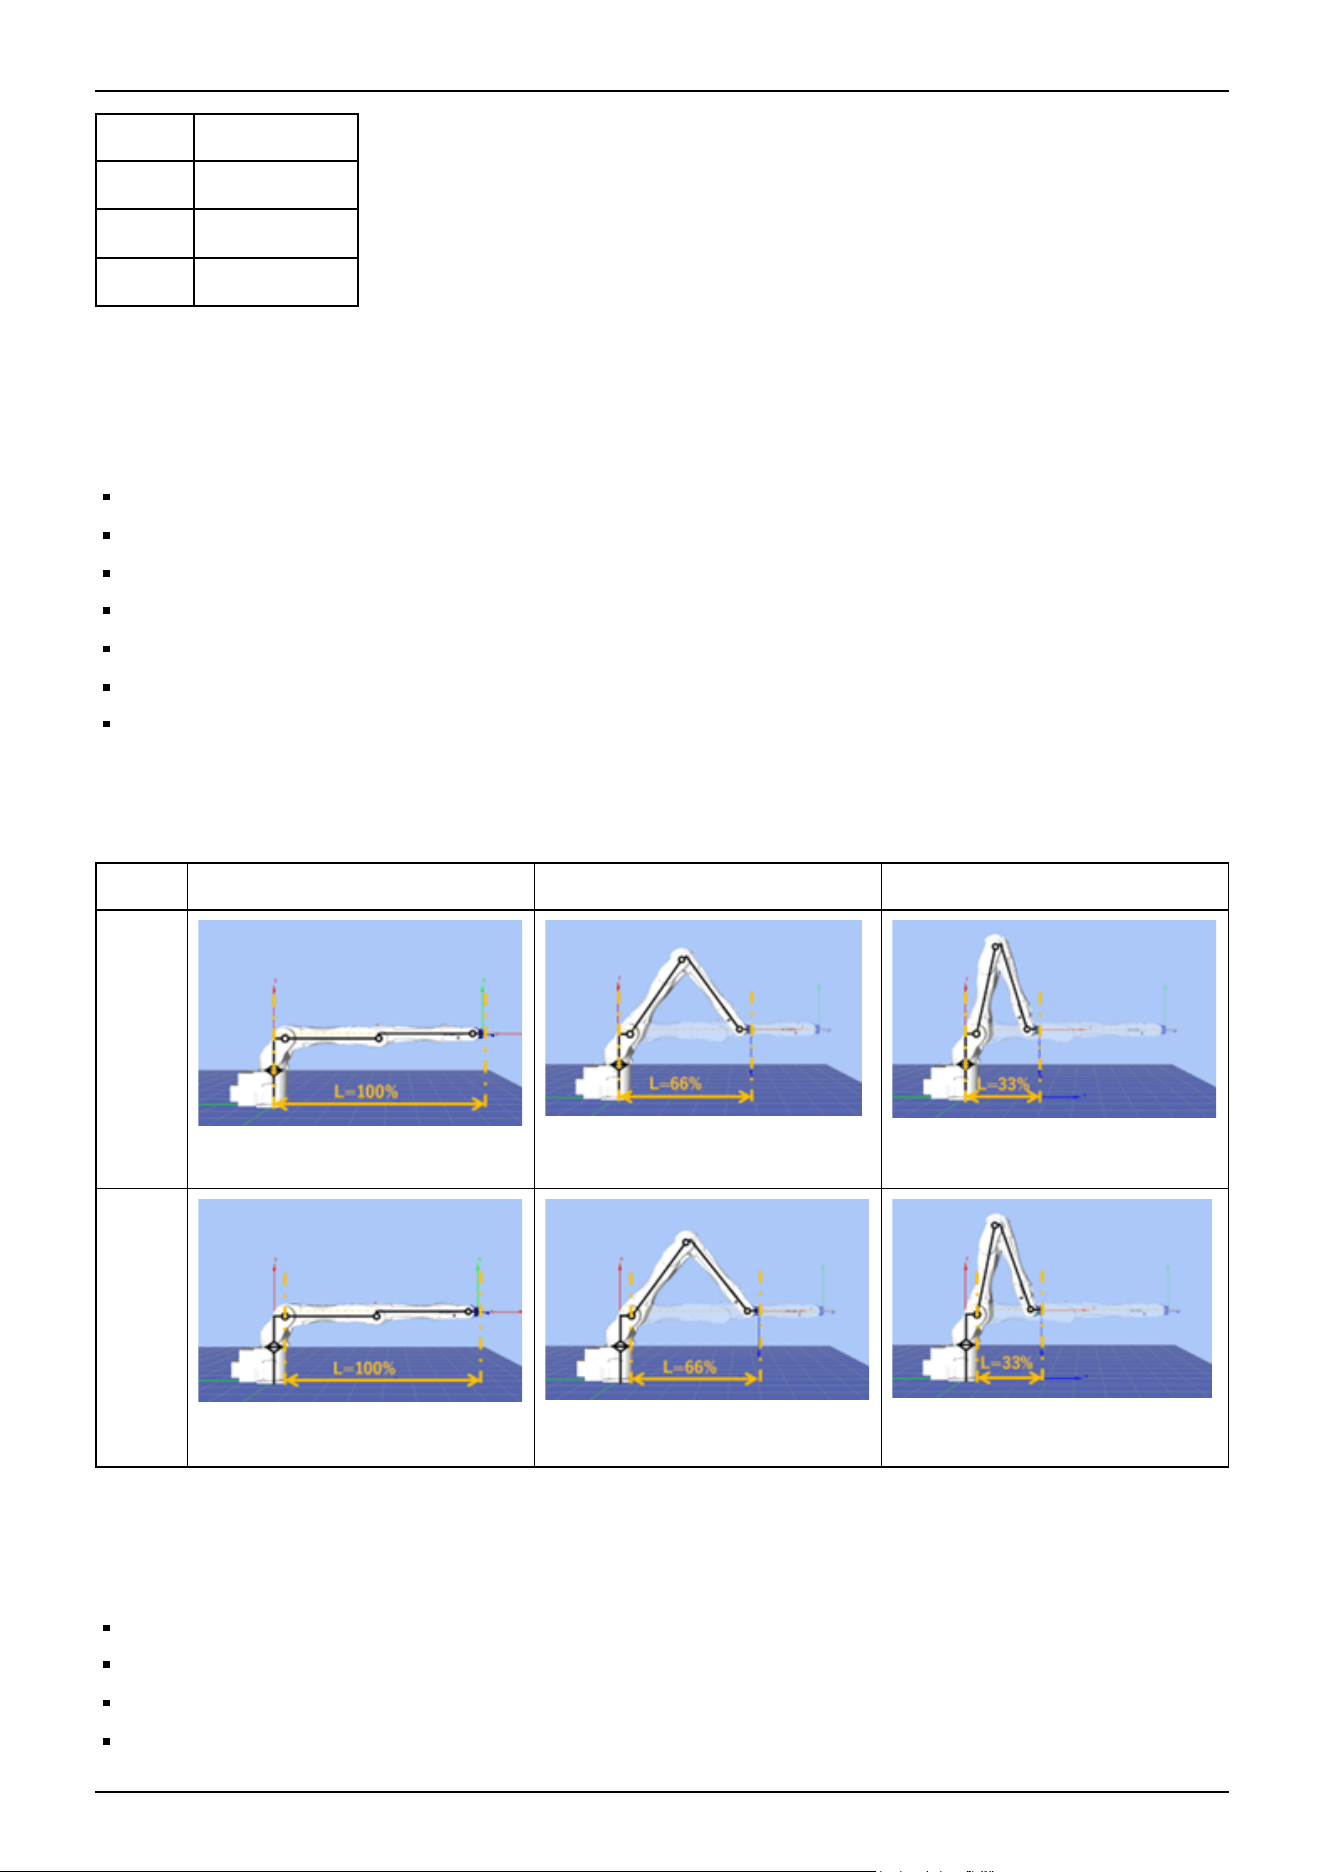
Symbol Description
b Safeguard open
c Time
d Stopping time
Conditions
The stopping time and stopping distance depend on the parameters (setting values) that were set for the robot. These graphs
show the times and distances for the following parameters.
These conditions are based on the ISO 10218-1:2011 Annex B.
Accel: 100, 100
Speed: 100 %, 66 %, 33 %Settings
Weight: 100 %, 66 %, 33 % of the maximum payload, rated payload
Arm elongation rate: 100 %, 66 %, 33 % *1
Other settings: Default
Motion: Singular axis motion of a Go command
Input timing of the Stop signal: input with maximum speed. In this motion, it is the center of the motion range.
*1 Arm elongation rate
The arm elongation rate L is as shown below: The graphs indicate the results where the stopping time and the stopping distance
in the longest among the arm elongation rates.
Axis L=100% L=66% L=33%
J1
J2
Explanation of legend
The graphs are displayed for each Weight setting value (at 100%, approx. 66%, and approx. 33% of the maximum payload, and
at the rated payload).
Horizontal axis: Arm speed (Speed setting)
Vertical axis: Stopping time and stopping distance at each arm speed
Time (sec): Stopping time (sec)
Distance (deg): stopping distance (degree)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
175
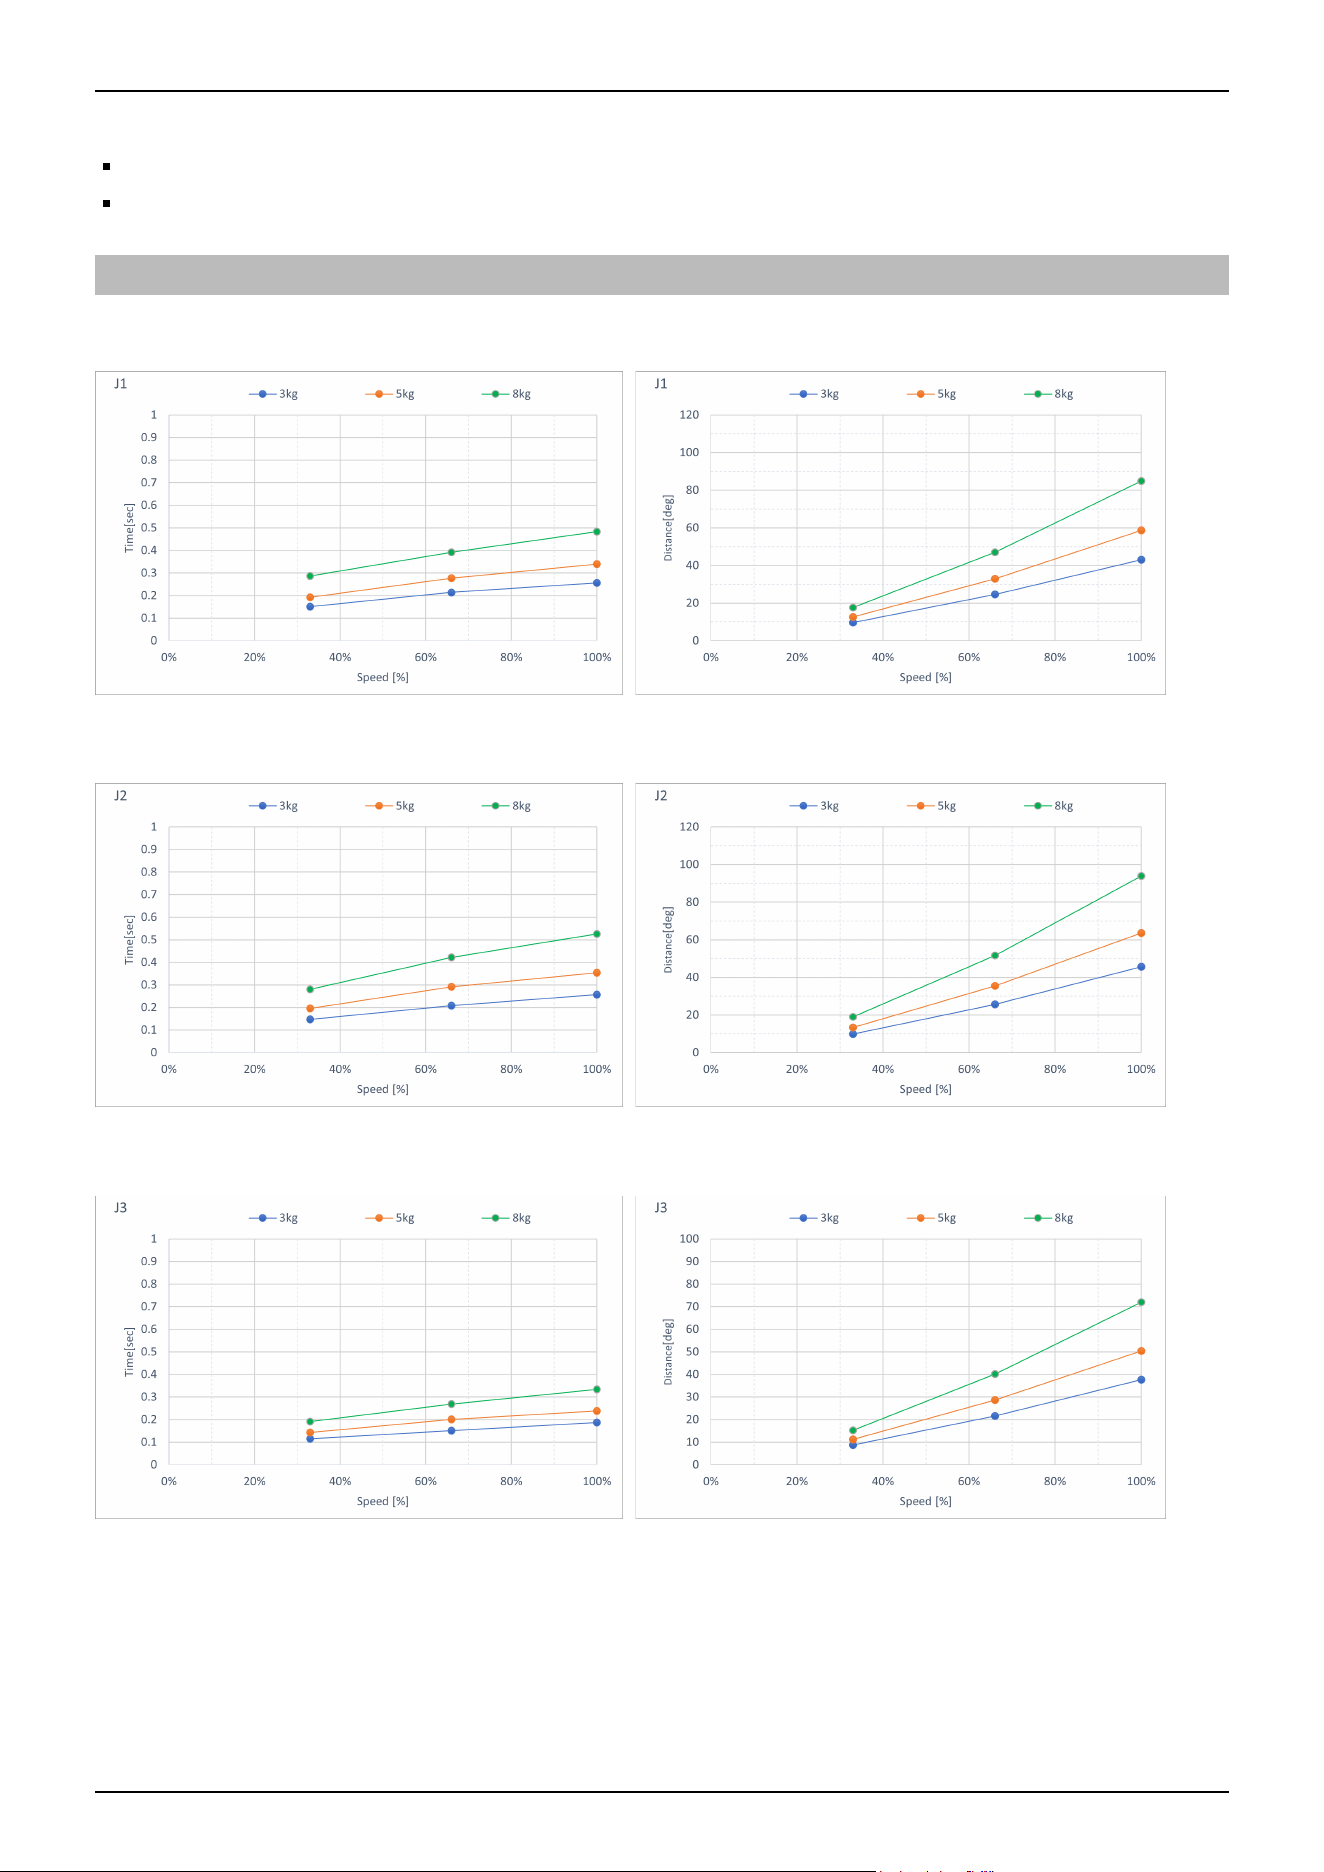
When single failures are taken into account, the following adjustments are used.
Stopping distance and angle: Each axis reaches the mechanical stop
Stopping time: Add 500 ms
5.3.1 C8-C Stopping Time and Stopping Distance When Safeguard is Open
C8-C901***: J1 (Table top mounting, Ceiling mounting)
C8-C901***: J2 (Table top mounting, Ceiling mounting)
C8-C901***: J3 (Table top mounting, Ceiling mounting)
C8-C901***: J4 (Table top mounting, Ceiling mounting)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
176
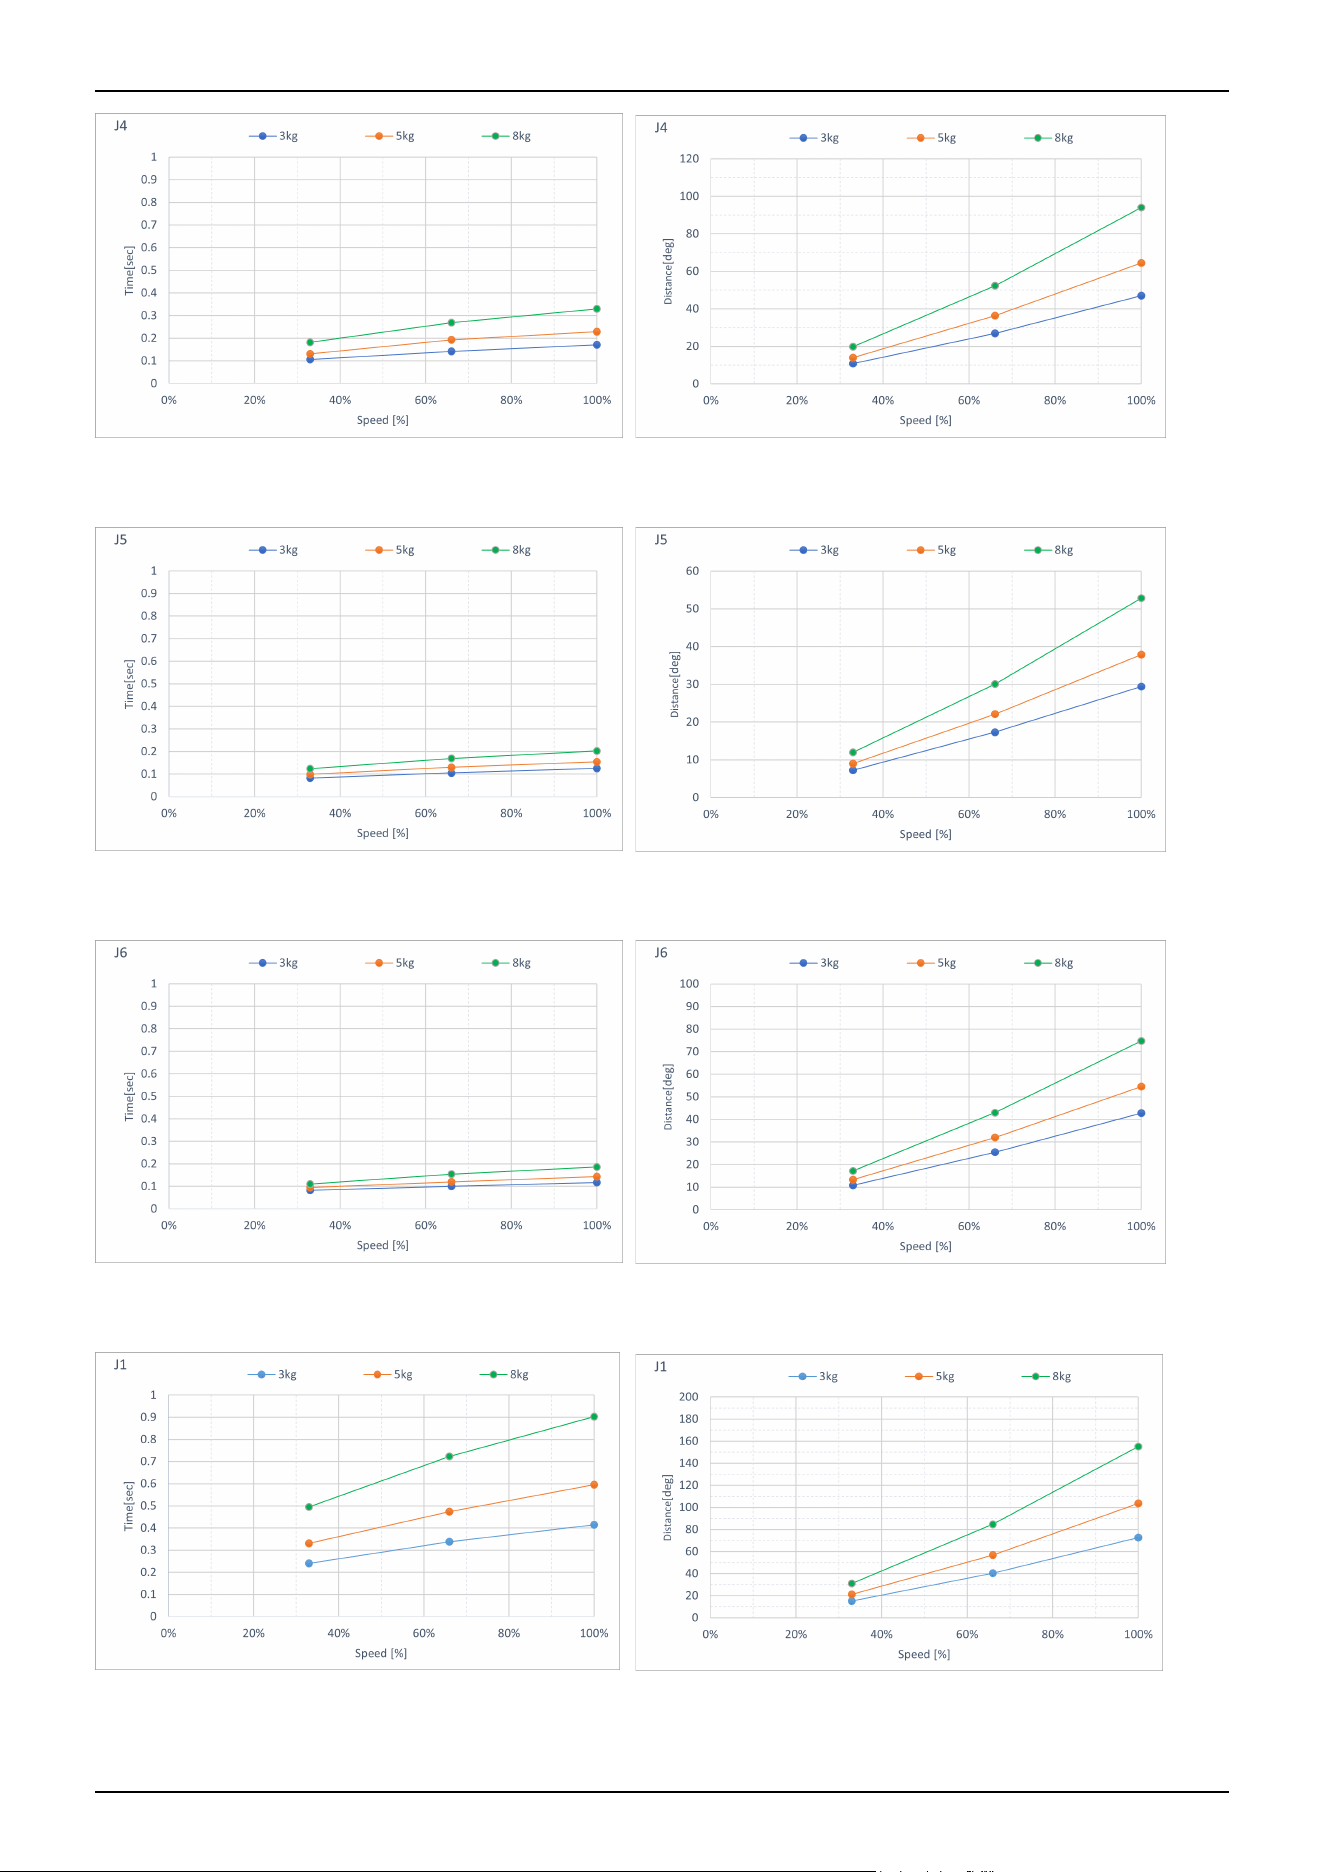
C8-C901***: J5 (Table top mounting, Ceiling mounting)
C8-C901***: J6 (Table top mounting, Ceiling mounting)
C8-C901***: J1 (Wall mounting)
C8-C901***: J2 (Wall mounting)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
177
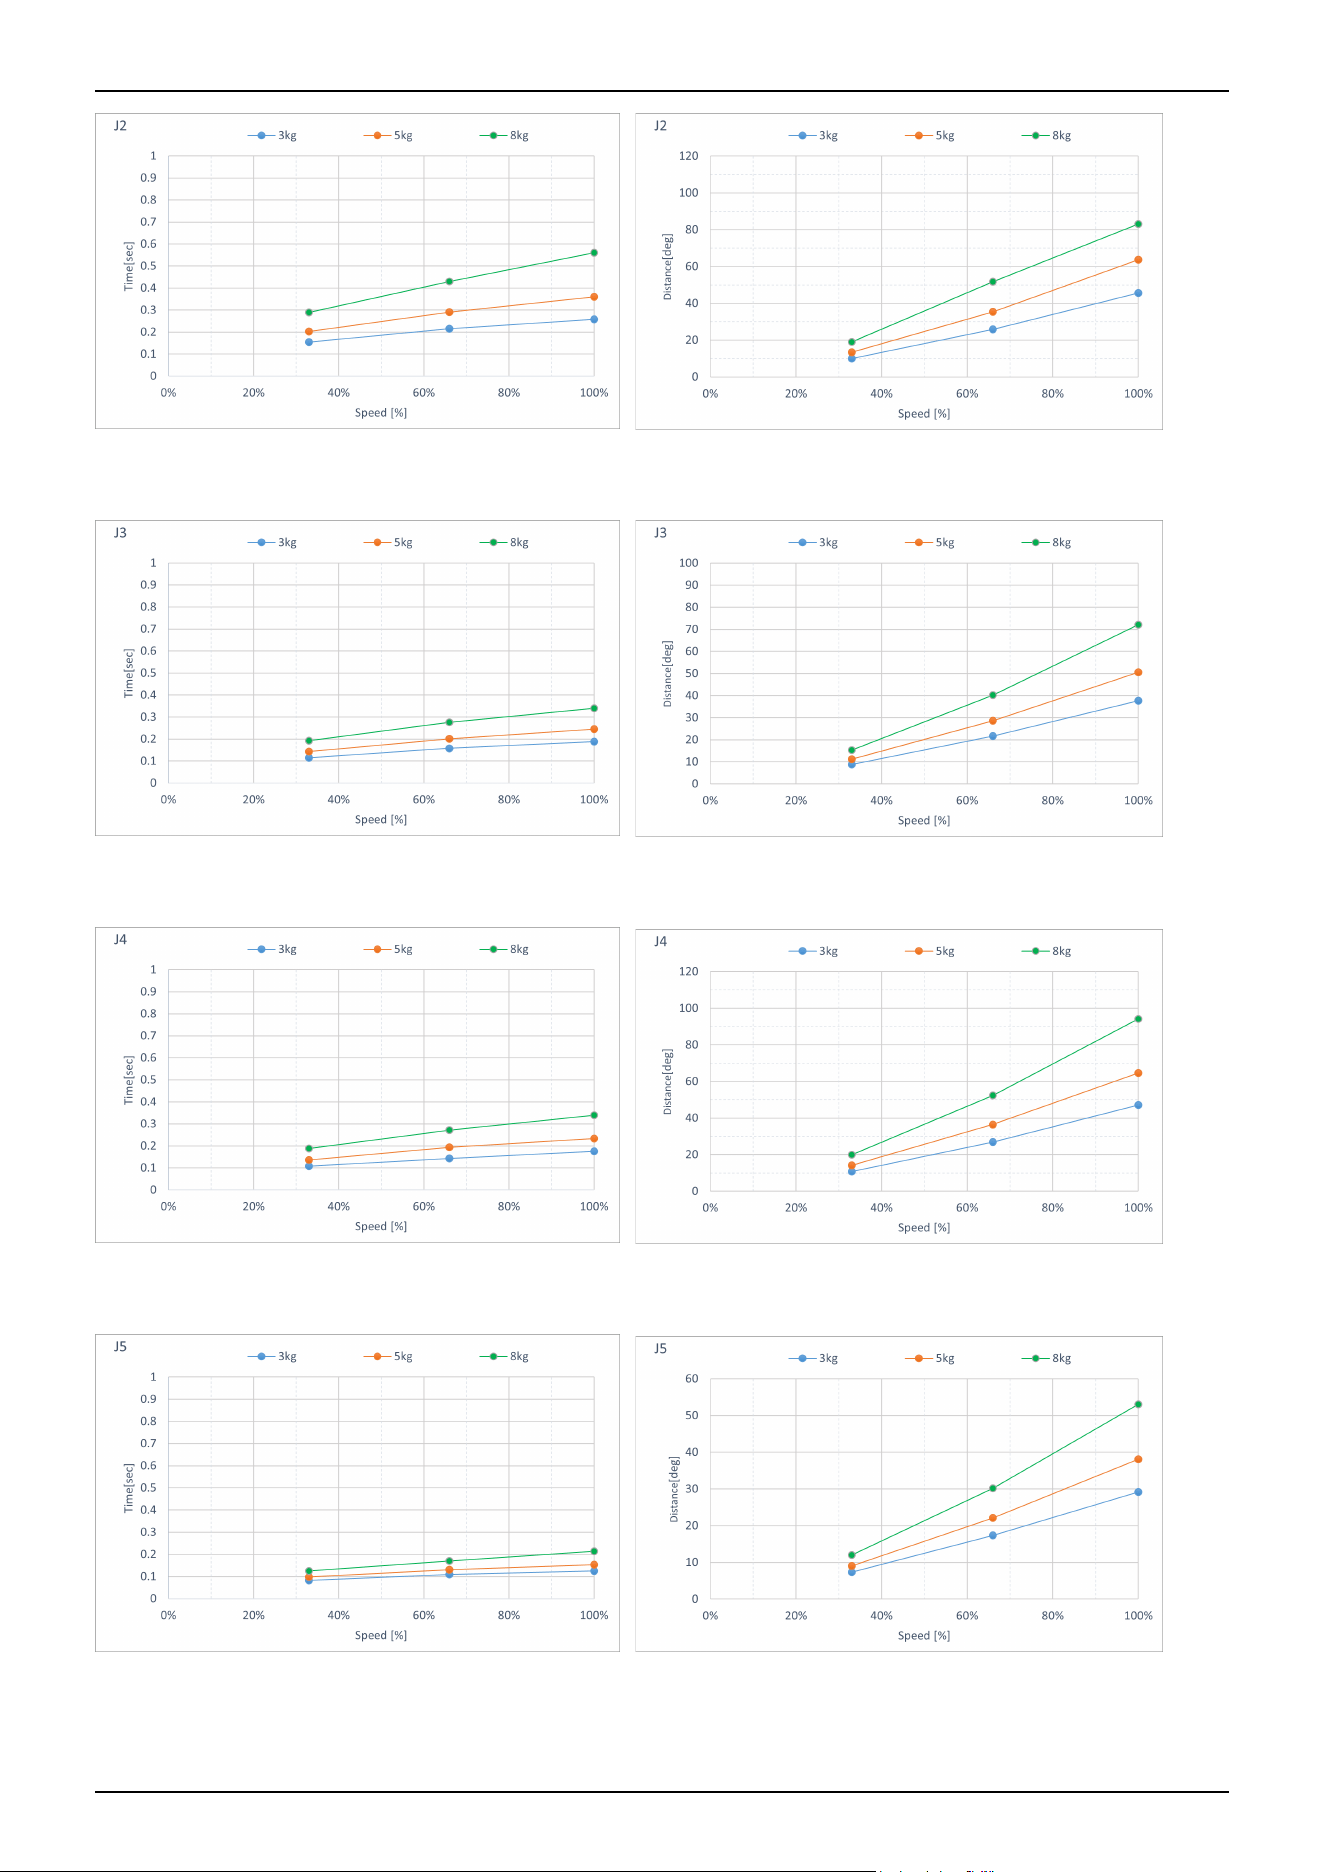
C8-C901***: J3 (Wall mounting)
C8-C901***: J4 (Wall mounting)
C8-C901***: J5 (Wall mounting)
C8-C901***: J6 (Wall mounting)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
178
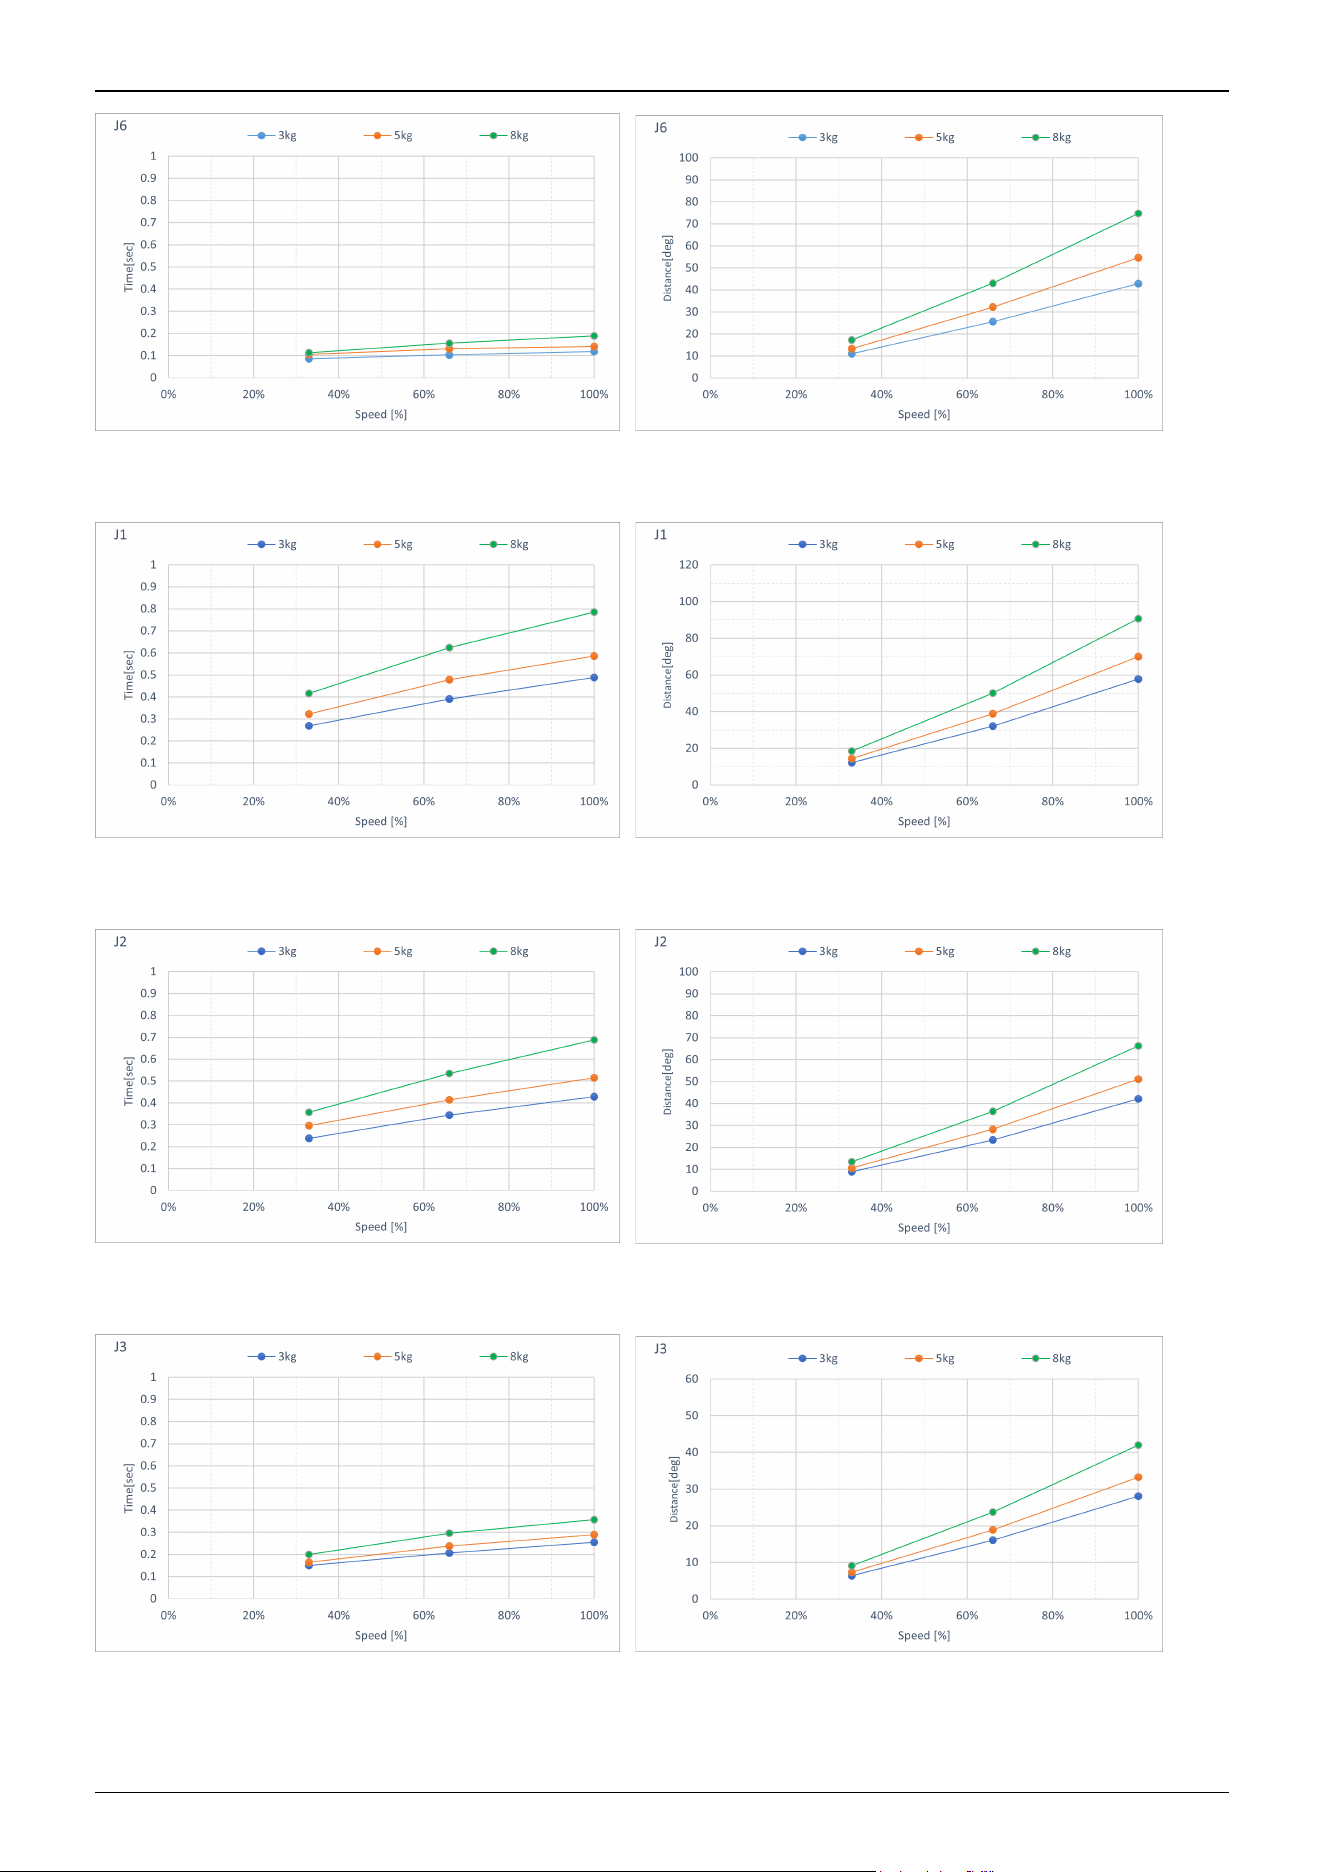
C8-C1401***: J1 (Table top mounting, Ceiling mounting)
C8-C1401***: J2 (Table top mounting, Ceiling mounting)
C8-C1401***: J3 (Table top mounting, Ceiling mounting)
C8-C1401***: J4 (Table top mounting, Ceiling mounting)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
179
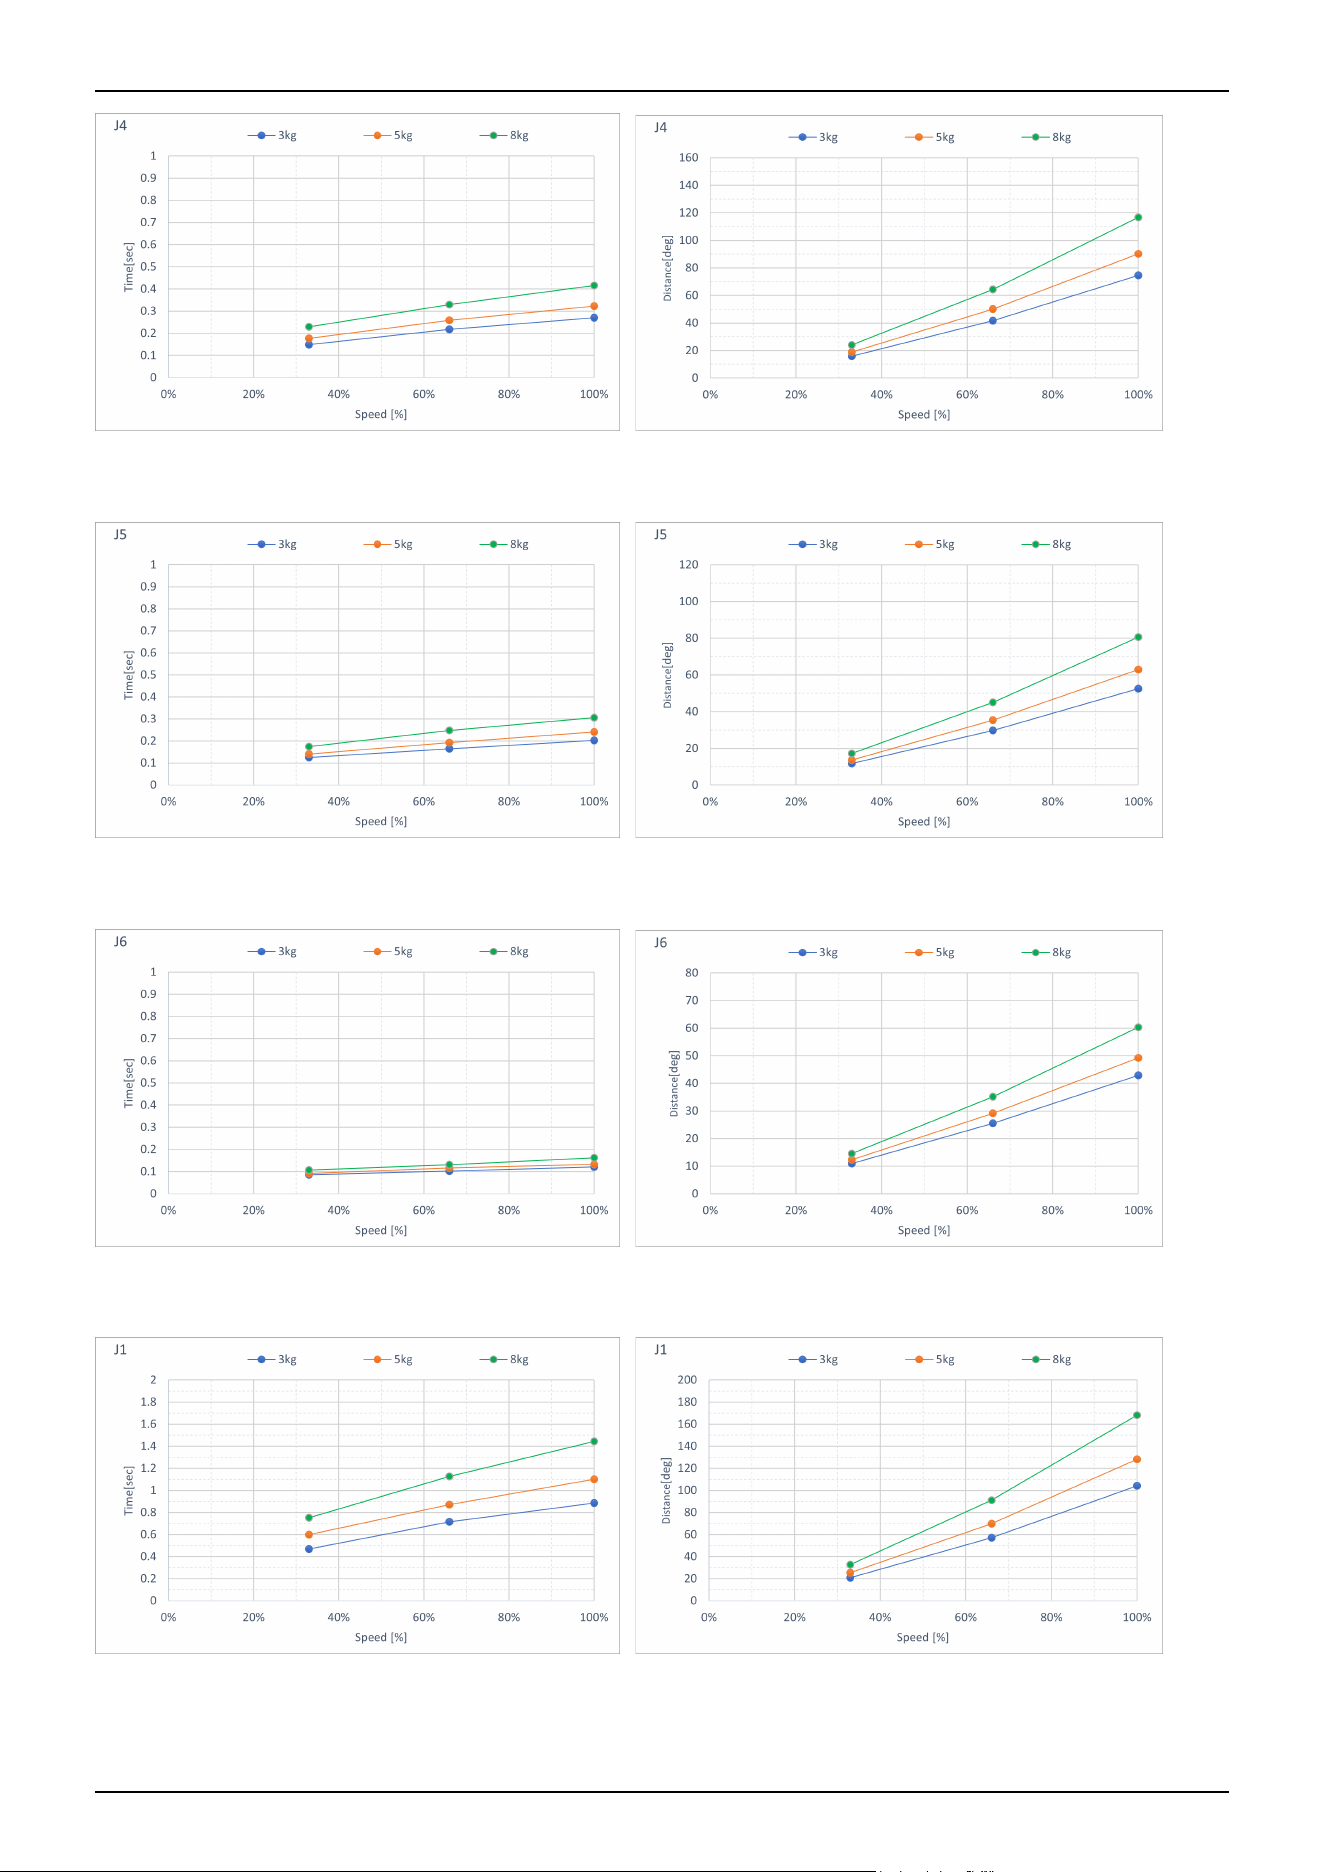
C8-C1401***: J5 (Table top mounting, Ceiling mounting)
C8-C1401***: J6 (Table top mounting, Ceiling mounting)
C8-C1401***: J1 (Wall mounting)
C8-C1401***: J2 (Wall mounting)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
180
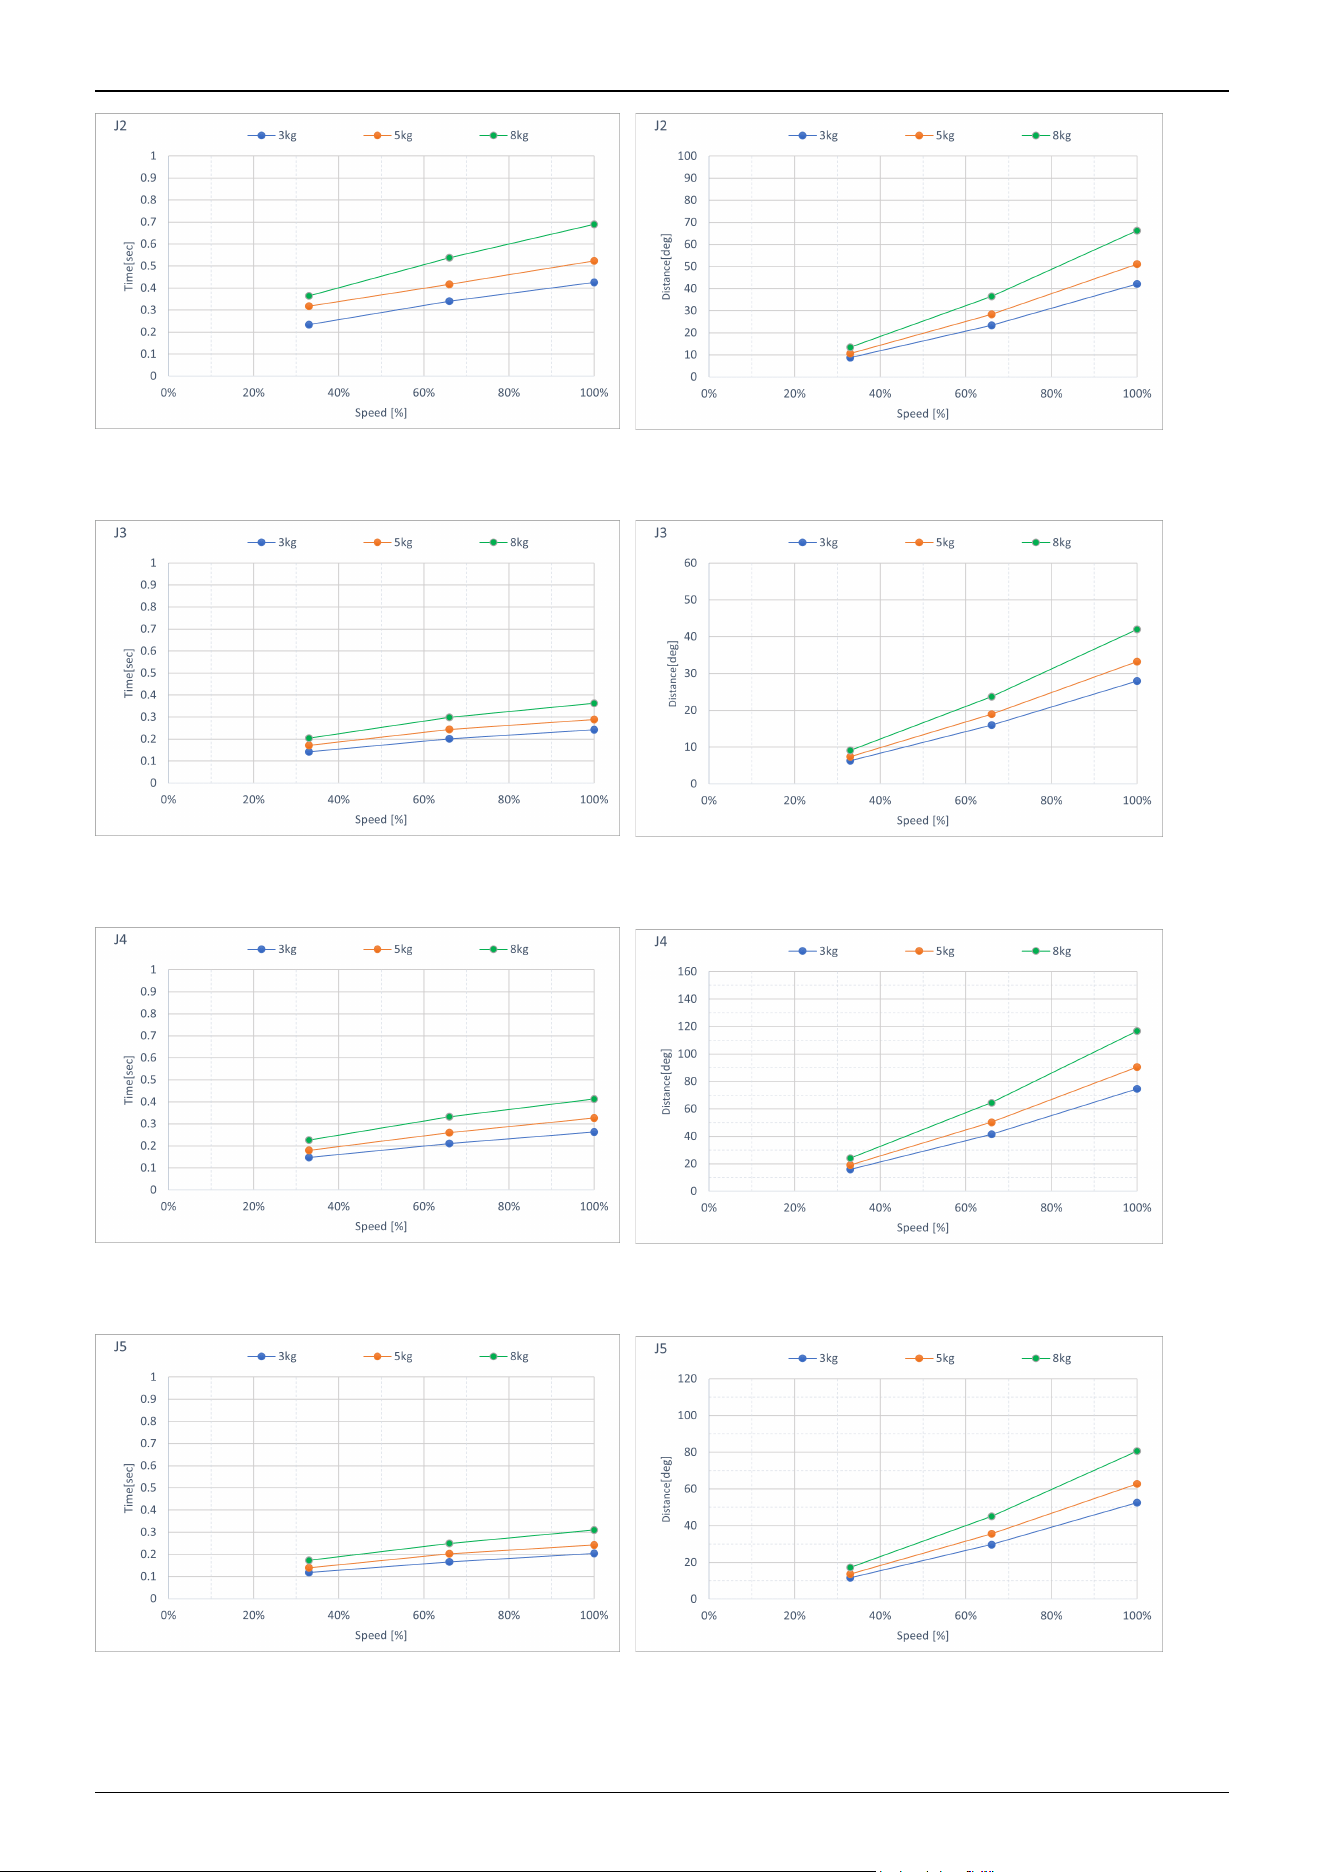
C8-C1401***: J3 (Wall mounting)
C8-C1401***: J4 (Wall mounting)
C8-C1401***: J5 (Wall mounting)
C8-C1401***: J6 (Wall mounting)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
181
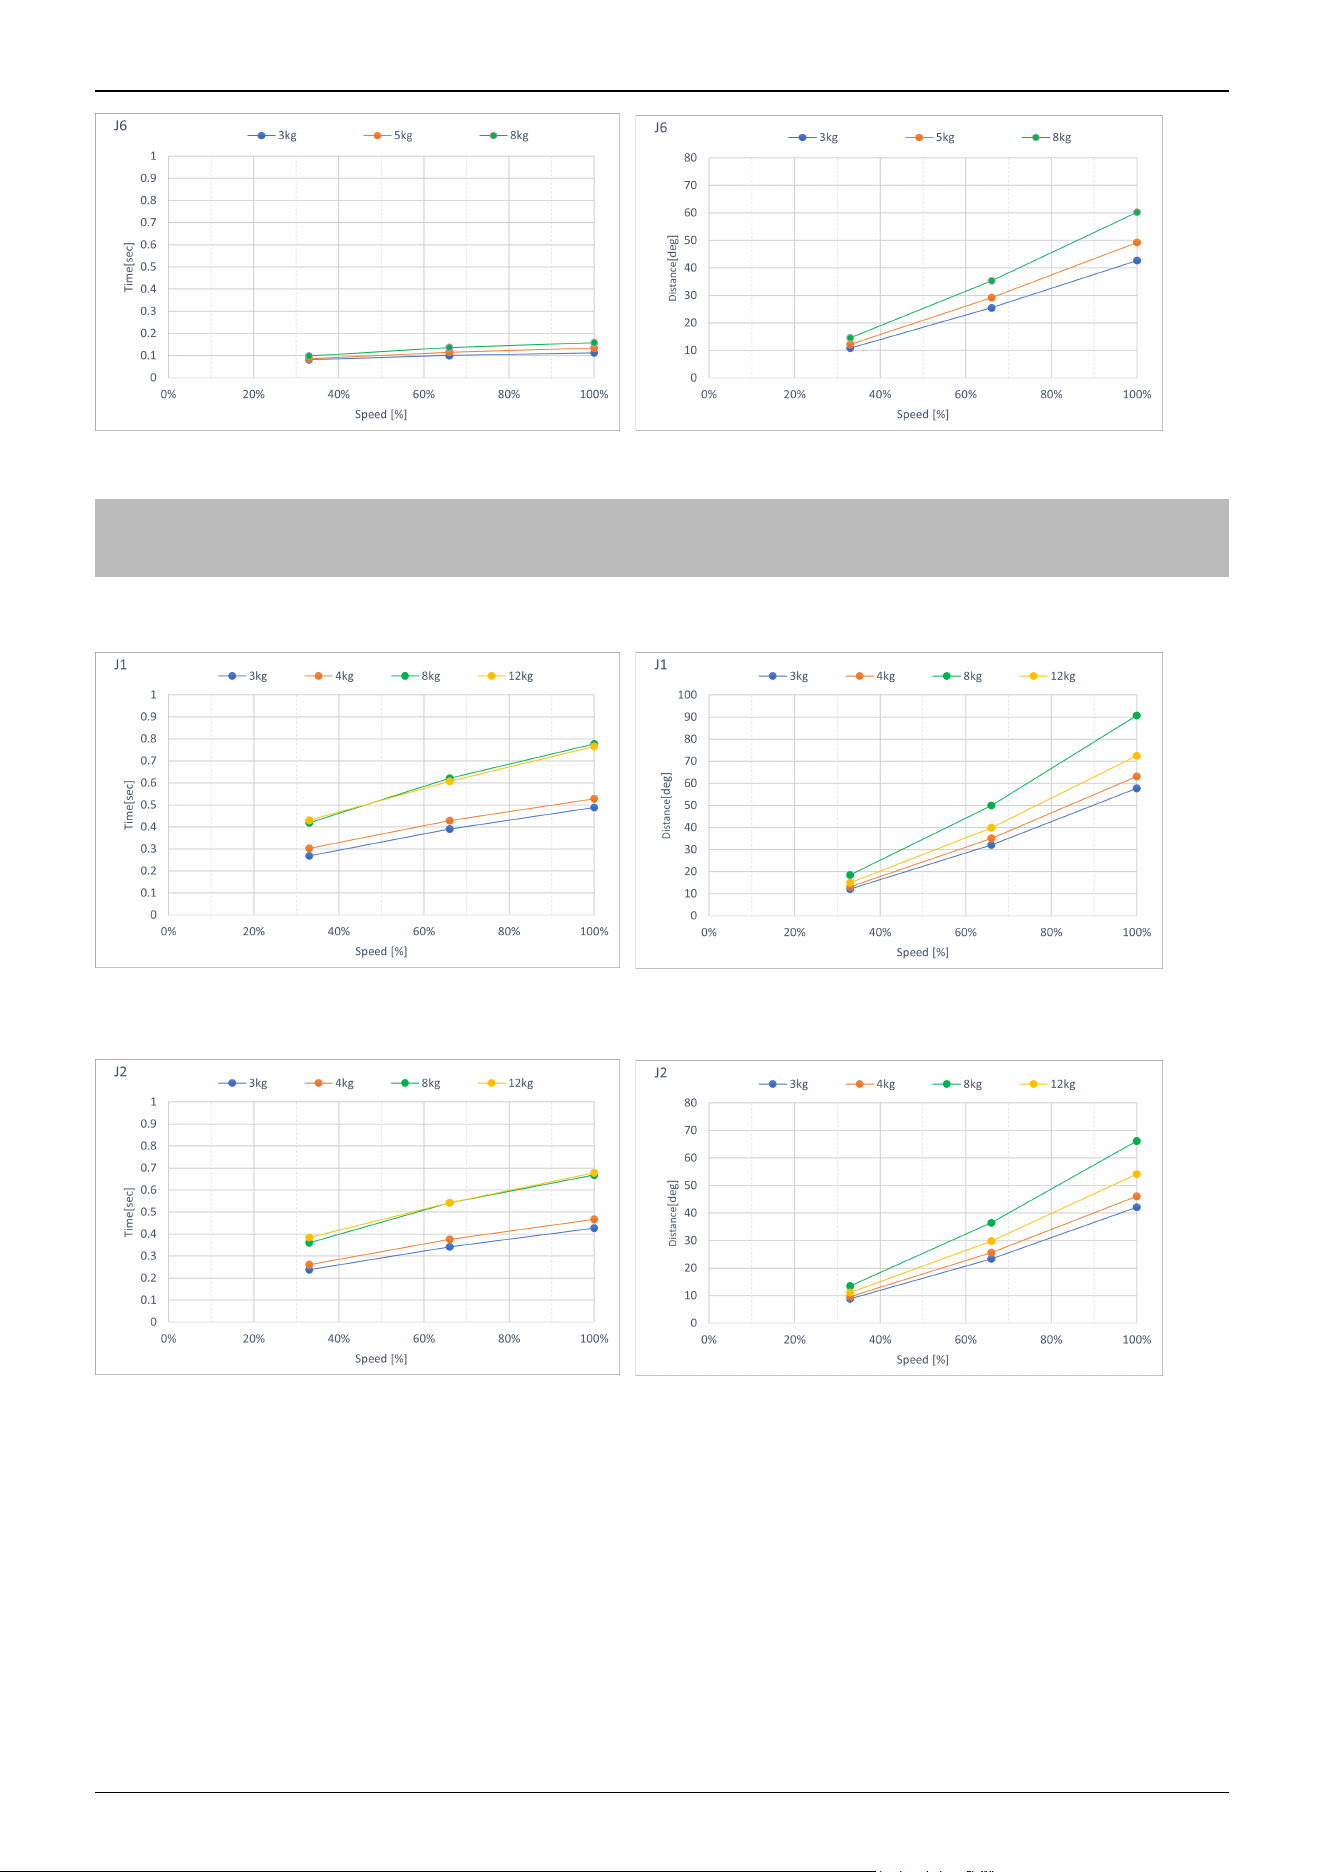
5.3.2 C12-C Stopping Time and Stopping Distance When Safeguard is
Open
C12-C1401**: J1 (Table top mounting)
C12-C1401**: J2 (Table top mounting)
C12-C1401**: J3 (Table top mounting)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
182
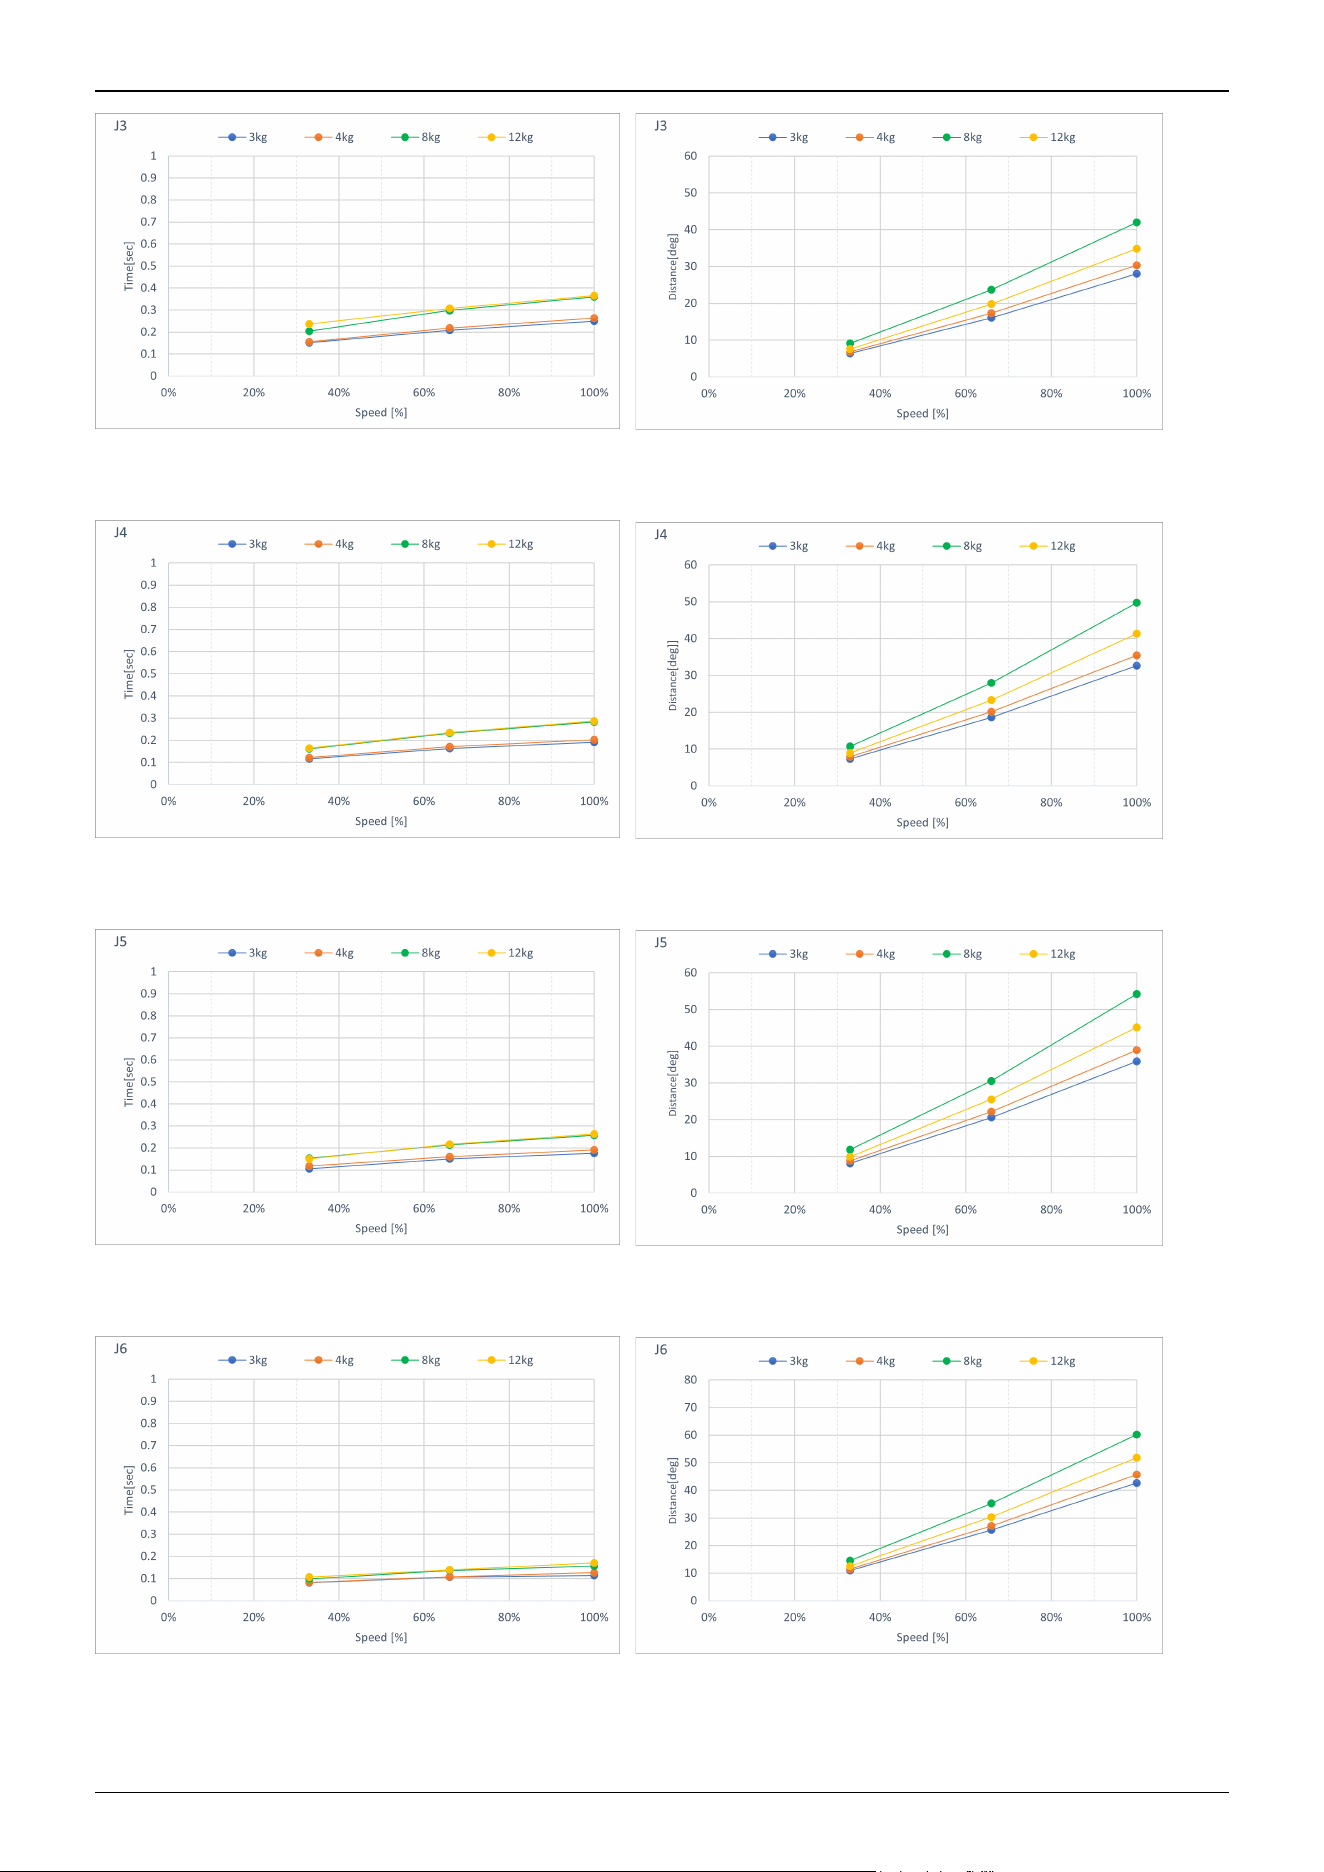
C12-C1401**: J4 (Table top mounting)
C12-C1401**: J5 (Table top mounting)
C12-C1401**: J6 (Table top mounting)
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
183
5.3.3 Supplementary Information regarding the Stopping Time and
Stopping Distance when the Safeguard is Open
The stopping time and stopping distance described in Appendix C was measured by the motion determined by us based on the
ISO 10218-1.
Therefore, it does not guarantee the maximum value of the stopping time and stopping distance in the customer’s environment.
The stopping time and stopping distance differs depending on the robot’s model, motion, and input timing of the stop signal.
Make sure to always measure the stopping time and stopping distance that matches the customer’s environment.
KEY POINTS
The following are included in the robot’s motion and parameter.
The motion’s starting point, target point, and relay point
Motion commands (Go, Move, Jump commands etc.)
Weight and Inertia Settings
Motion speed, acceleration, deceleration, and one where the motion timing changes
Also, refer to the following description.
C8:
WEIGHT and INERTIA Settings
Safety Information for Auto Acceleration
C12:
WEIGHT and INERTIA Settings
Safety Information for Auto Acceleration
5.3.3.1 How to check the stopping time and stopping distance in the customer’s
environment
Measure the stopping time and stopping distance of the actual motion with the following method.
1. Create a motion program in the customer’s environment.
2. After the motion to check the stopping time and stopping distance starts, input the stop signal at your own timing.
3. Record the time and distance from when the stop signal was input until the robot stopped.
4. Check the maximum stopping time and stopping distance by repeating 1 through 3 mentioned above.
How to input the stop signal: Operate the stop switch/safeguard manually or input the stop signal with the safety PLC.
How to measure the stopping position: Measure with a tape measure. The angle could also be measured with the Where or
RealPos command.
How to measure the stopping time: Measure with a stop watch. The Tmr function can also be used to measure the stopping
time.
CAUTION
The stopping time and stopping distance changes depending on the timing the stop signal is input.
In order to prevent collision with people or objects, perform a risk assessment based on the maximum stopping
time and stopping distance and perform an equipment design.
Therefore, make sure to measure the maximum value by changing the timing of the stop signal input during the
actual motion and measure repeatedly.
✏
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
184
To shorten the stopping time and stopping distance, use the Safety Limited Speed (SLS) and limit the maximum speed.
For details on the safety limited speed, refer to the following manual.
“Safety Function Manual“
5.3.3.2 Commands that can be useful when measuring stopping time and
stopping distance
Commands Functions
Where Returns the data of the robot’s current position
RealPos
Returns the current position of the specified robot
Unlike the motion target position of the CurPos, this obtains the position of the actual robot from the
encoder in real time.
PAgl
Returns by calculating the Joint position from the specified coordinate value.
P1 = RealPos 'Obtain the current position
Joint1 = PAgl (P1, 1) ‘ Request the J1 angle from the current position
SF_RealSpeedS Display the current speed from the limited speed position in mm/s.
Tmr The Tmr function returns the elapsed time from when the timer starts in seconds.
Xqt
Runs the program specified with the function name and complete the task.
The function used to measure the stopping time and stopping distance should be used to run tasks that
were launched by attaching the NoEmgAbort options. You can run a task that does not stop with the
emergency stop and safeguard open.
For more information, refer to the following manual.
"Epson RC+ SPEL+ Language Reference"
Industrial Robot: 6-Axis Robots C-C series Manual Rev.2
185