Rev.4 EM204R4269F
SCARA ROBOT
LS20-B series
MANIPULATOR MANUAL
MANIPULATOR MANUAL
LS20-B series Rev.4
LS20-B Rev.4 i
SCARA ROBOT
LS20-B series Manipulator Manual
Rev.4
Copyright 2019-2020 SEIKO EPSON CORPORATION. All rights reserved.
ii L
S20-B Rev.4
FOREWORD
Thank you for purchasing our robot products.
This manual contains the information necessary for the correct use of the manipulator.
Please carefully read this manual and other related manuals before installing the robot
system.
Keep this manual handy for easy access at all times.
WARRANTY
The Manipulator and its optional parts are shipped to our customers only after being
subjected to the strictest quality controls, tests, and inspections to certify its compliance with
our high performance standards.
Product malfunctions resulting from normal handling or operation will be repaired free of
charge during the normal warranty period. (Please contact the supplier of your region for
warranty period information.)
However, customers will be charged for repairs in the following cases (even if they occur
during the warranty period):
1.
Damage or malfunction caused by improper use which is not described in the manual, or
careless use.
2.
Malfunctions caused by customers
’ unauthorized disassembly.
3.
Damage due to improper adjustments or unauthorized repair attempts.
4.
Damage caused by
natural disasters such as earthquake, flood, etc.
Warnings, Cautions, Usage:
1.
If the Manipulator or associated equipment is used outside of the usage conditions and
product specifications described in the manuals, this warranty is void.
2.
If you do not follow the WARNINGS and CAUTIONS in this manual, we cannot be
responsible for any malfunction or accident, even if the result is injury or death.
3.
We cannot foresee all possible dangers and consequences. Therefore, this manual cannot
warn the use
r of all possible hazards.
LS20-B Rev.4 iii
TRADEMARKS
Microsoft, Windows, and Windows logo are either registered trademarks or trademarks of
Microsoft Corporation in the United States and/or other countries. Other brand and
product names are trademarks or registered trademarks of the respective holders.
NOTICE
No part of this manual may be copied or reproduced without authorization.
The contents of this manual are subject to change without notice.
Please notify us if you should find any errors in this manual or if you have any comments
regarding its contents.
MANUFACTURER
CONTACT INFORMATION
Contact information is described in “SUPPLIERS” in the first pages of the following
manual:
Robot System Safety and Installation Read this manual first
iv L
S20-B Rev.4
Regarding battery disposal
T
he crossed out wheeled bin label that can be found on your product indicates that this
product and incorporated batteries should not be disposed of via the normal household waste
stream. To prevent possible harm to the environment or human health please separate this
product and its batteries from other waste streams to ensure that it can be recycled in an
environmentally sound manner. For more details on available collection facilities please
contact your local government office or the retailer where you purchased this product. Use
of the chemical symbols Pb, Cd or Hg indicates if these metals are used in the battery.
This information only applies to customers in the European Union, according to
DIRECTIVE 2006/66/EC OF THE EUROPEAN PARLIAMENT AND OF THE
COUNCIL OF 6 September 2006 on batteries and accumulators and waste batteries and
accumulators and repealing Directive 91/157/EEC and legislation transposing and
implementing it into the various national legal systems.
For other countries, please contact your local government to investigate the possibility of
recycling your product.
The battery removal/replacement procedure is described in the following manuals:
Controller manual Maintenance section
LS20-B Rev.4 v
Before Reading This Manual
This section describes what you should know before reading this manual.
Structure of Control System
The LS20-B series Manipulators can be used with the following combinations of Controllers
and software.
Controller : RC90-B
Software : EPSON RC+ 7.0 Ver.7.4.5 or later
Turning ON/OFF Controller
When you see the instruction “Turn ON/OFF the Controller” in this manual, be sure to turn
ON/OFF all the hardware components. For the Controller composition, refer to the table
above.
Shape of Motors
The shape of the motors used for the Manipulator that you are using may be different from
the shape of the motors described in this manual because of the specifications.
Setting by Using Software
This manual contains setting procedures by using software. They are marked with the
following icon.
Figures in this Manual
The figures of manipulators indicated in this manual are basically Standard-model
Manipulator. Unless special instruction is provided, the specifications of Standard-model
and Cleanroom-model are the same.
Pictures in this Manual
Pictures and illustrations of the manipulator in this manual may differ from using
manipulator depending on the shipment date and the specifications.
EPSON
RC+
vi L
S20-B Rev.4
TABLE OF CONTENTS
LS20-B Rev.4 vii
Setup & Operation
1. Safety 3
1.1 Conventions.............................................................................................. 3
1.2 Design and Installation Safety .................................................................. 4
1.2.1 Strength of the Ball Screw Spline ................................................. 5
1.3 Operation Safety ...................................................................................... 6
1.4 Emergency Stop ....................................................................................... 8
1.5 Emergency Movement without Drive Power .......................................... 10
1.6 ACCELS Setting for CP Motions ............................................................. 11
1.7 Warning Labels ....................................................................................... 12
2. Specifications 14
2.1 Features of LS20-B series Manipulators ................................................ 14
2.2 Model Number ........................................................................................ 15
2.3 Part Names and Outer Dimensions ....................................................... 16
2.3.1 Standard-Model (LS20-B**4S) ................................................... 16
2.3.2 Cleanroom-Model (LS20-B**4C) ................................................ 18
2.4 Specifications ......................................................................................... 20
2.5 How to Set the Model ............................................................................. 22
3. Environments and Installation 23
3.1 Environmental Conditions ...................................................................... 23
3.2 Base Table .............................................................................................. 24
3.3 Mounting Dimensions ............................................................................. 25
3.4 Unpacking and Transportation ............................................................... 26
3.5 Installation Procedure............................................................................. 28
3.5.1 Standard-Model .......................................................................... 28
3.5.2 Cleanroom-Model ....................................................................... 29
3.6 Connecting the Cables ........................................................................... 29
3.7 User Wires and Pneumatic Tubes.......................................................... 31
3.8 Relocation and Storage .......................................................................... 33
3.8.1 Precautions for Relocation and Storage .................................... 33
3.8.2 Relocation ................................................................................... 35
4. Setting of End Effectors 36
4.1 Attaching an End Effector....................................................................... 36
4.2 Attaching Cameras and Valves .............................................................. 37
4.3 Weight and Inertia Settings .................................................................... 38
4.3.1 Weight Setting ............................................................................ 38
4.3.2 Inertia Setting ............................................................................. 41
4.4 Precautions for Auto Acceleration/Deceleration of Joint #3 ................... 46
TABLE OF CONTENTS
vi
ii LS20-B Rev.4
5. Motion Range 47
5.1 Motion Range Setting by Pulse Range ................................................... 47
5.1.1 Max. Pulse Range of Joint #1 ..................................................... 48
5.1.2 Max. Pulse Range of Joint #2 ..................................................... 48
5.1.3 Max. Pulse Range of Joint #3 ..................................................... 49
5.1.4 Max. Pulse Range of Joint #4 ..................................................... 49
5.2 Motion Range Setting by Mechanical Stops ........................................... 50
5.2.1 Setting the Mechanical Stops of Joints #1 and #2 ...................... 51
5.2.2 Setting the Mechanical Stop of Joint #3 ..................................... 53
5.3 Setting the Cartesian (Rectangular) Range in the XY Coordinate System
of the Manipulator (for Joints #1 and #2)………………………………….55
5.4 Standard Motion Range .......................................................................... 56
Maintenance
1. Safety Maintenance 61
2. General Maintenance 62
2.1 Maintenance Inspection .......................................................................... 62
2.1.1 Schedule for Maintenance Inspection ......................................... 62
2.1.2 Inspection Point ........................................................................... 63
2.2 Overhaul (Parts Replacement) ............................................................... 64
2.3 Greasing .................................................................................................. 66
2.4 Tightening Hexagon Socket Head Cap Bolts ......................................... 67
2.5 Matching Origins ..................................................................................... 67
2.6 Layout of Maintenance Parts .................................................................. 68
3. Covers 69
3.1 Arm Top Cover ........................................................................................ 70
3.2 Arm Bottom Cover ................................................................................... 71
3.3 Arm #1 Cover .......................................................................................... 71
3.4 Connector Plate ...................................................................................... 72
3.5 Connector Sub Plate ............................................................................... 73
3.6 User Plate................................................................................................ 74
3.7 Duct Plate ................................................................................................ 74
4. Cable 75
4.1 Replacing Cable Unit .............................................................................. 76
4.2 Wiring Diagrams ...................................................................................... 82
4.2.1 Signal Cable ................................................................................ 82
4.2.2 Power Cable ................................................................................ 83
4.2.3 User Cable .................................................................................. 84
4.2.4 Color of Cables............................................................................ 85
4.3 Replacing M/C Cable .............................................................................. 86
TABLE OF CONTENTS
LS20-B Rev.4 ix
5. Joint #1 91
5.1 Replacing Joint #1 Motor ....................................................................... 92
5.2 Replacing Joint #1 Reduction Gear Unit ................................................ 96
6. Joint #2 99
6.1 Replacing Joint #2 Motor ..................................................................... 100
6.2 Replacing Joint #2 Reduction Gear Unit .............................................. 104
7. Joint #3 108
7.1 Replacing Joint #3 Motor ..................................................................... 109
7.2 Replacing the Timing Belt ..................................................................... 113
7.3 Replacing the Brake .............................................................................. 118
7.4 Checking the Timing Belt Tension (Z Belt) ........................................... 123
8. Joint #4 124
8.1 Replacing Joint #4 Motor ..................................................................... 125
8.2 Replacing the Timing Belt .................................................................... 130
8.3 Replacing the Brake ............................................................................. 135
8.4 Replacing the Reduction Gear Unit ..................................................... 141
8.5 Checking the Timing Belt Tension (U Belt) ........................................... 144
9. Bellows 145
10. Ball Screw Spline Unit 147
10.1 Greasing the Ball Screw Spline Unit .................................................. 147
10.1.1 Standard-model ...................................................................... 148
10.1.2 Cleanroom-model ................................................................... 149
10.2 Replacing the Ball Screw Spline Unit ................................................. 150
11. Boards 153
11.1 Replacing the Converter Board .......................................................... 154
11.2 Replacing the Control Board .............................................................. 155
12. LED Lamp 156
13. Calibration 157
13.1 About Calibration ................................................................................ 157
13.2 Calibration Procedure......................................................................... 158
13.3 Accurate Calibration of Joint #2 ......................................................... 168
13.4 Calibration Procedure without using Calibration Wizard ................... 170
14. Maintenance Parts List 174
TABLE OF CONTENTS
x
LS20-B Rev.4
Setup & Operation
This volume contains information for setup and operation of the LS20-B series Manipulators.
Please read this volume thoroughly before setting up and operating the Manipulators.
Setup & Operation 1. Safety
LS20-B Rev.4 3
1. Safety
Installation and transportation of manipulators and robotic equipment shall be performed by
qualified personnel and should conform to all national and local codes.
Please read this manual and other related manuals before installing the robot system or
before connecting cables.
Keep this manual handy for easy access at all times.
1.1 Conventions
Important safety considerations are indicated throughout the manual by the following
symbols. Be sure to read the descriptions shown with each symbol.
WARNING
This symbol indicates that a danger of possible serious injury or
death exists if the associated instructions are not followed
properly.
WARNING
This symbol indicates that a danger of possible serious injury or
death caused by electric shock exists if the associated
instructions are not followed properly.
CAUTION
This symbol indicates that a danger of possible harm to people
or physical damage to equipment
and facilities exists if the
associated instructions are not followed properly.
Setup & Operation 1. Safety
4
LS20-B Rev.4
1.2 Design and Installation Safety
Only trained personnel should design and install the robot system. Trained
personnel are defined as those who have taken robot system training and
maintenance training classes held by the manufacturer, dealer, or local
representative company, or those who understand the manuals thoroughly and
have the same knowledge and skill level as those who have completed the training
courses.
To ensure safety, a safeguard must be installed for the robot system. For details
on the safeguard, refer to the Installation and Design Precautions in the Safety
chapter of the EPSON RC+ User’s Guide.
The following items are safety precautions for design personnel:
WARNING
■
Personnel who design and/or construct the robot system with this product must
read the
Safety chapter in the EPSON RC+ User’s Guide to understand the safety
requirements before designing and/or constructing the robot system. Designing
and/or constructing the robot system without understanding the safety
requirements is extremely hazardous, may result in serious bodily injury and/or
se
vere equipment damage to the robot system, and may cause serious safety
problems.
■
The Manipulator and the Controller must be used within the environmental
conditions described in their respective manuals.
This product has been
designed and manufactured strictly for use in a normal indoor environment. Using
the product in an environment
that exceeds the specified environmental conditions
may not only shorten the life cycle of the product but may also cause serious
safety problems.
■
The robot system must be used within the installation requirements described in
the manuals.
Using the robot system outside of the installation requirements
may not only shorten the life cycle of the product but also cause serious safety
problems.
Further precautions for installation are mentioned in the chapter Setup & Operation:
3. Environments and Installation. Please read this chapter carefully to understand
safe installation procedures before installing the robots and robotic equipment.
Setup & Operation 1. Safety
LS20-B Rev.4 5
1.2.1 Strength of the Ball Screw Spline
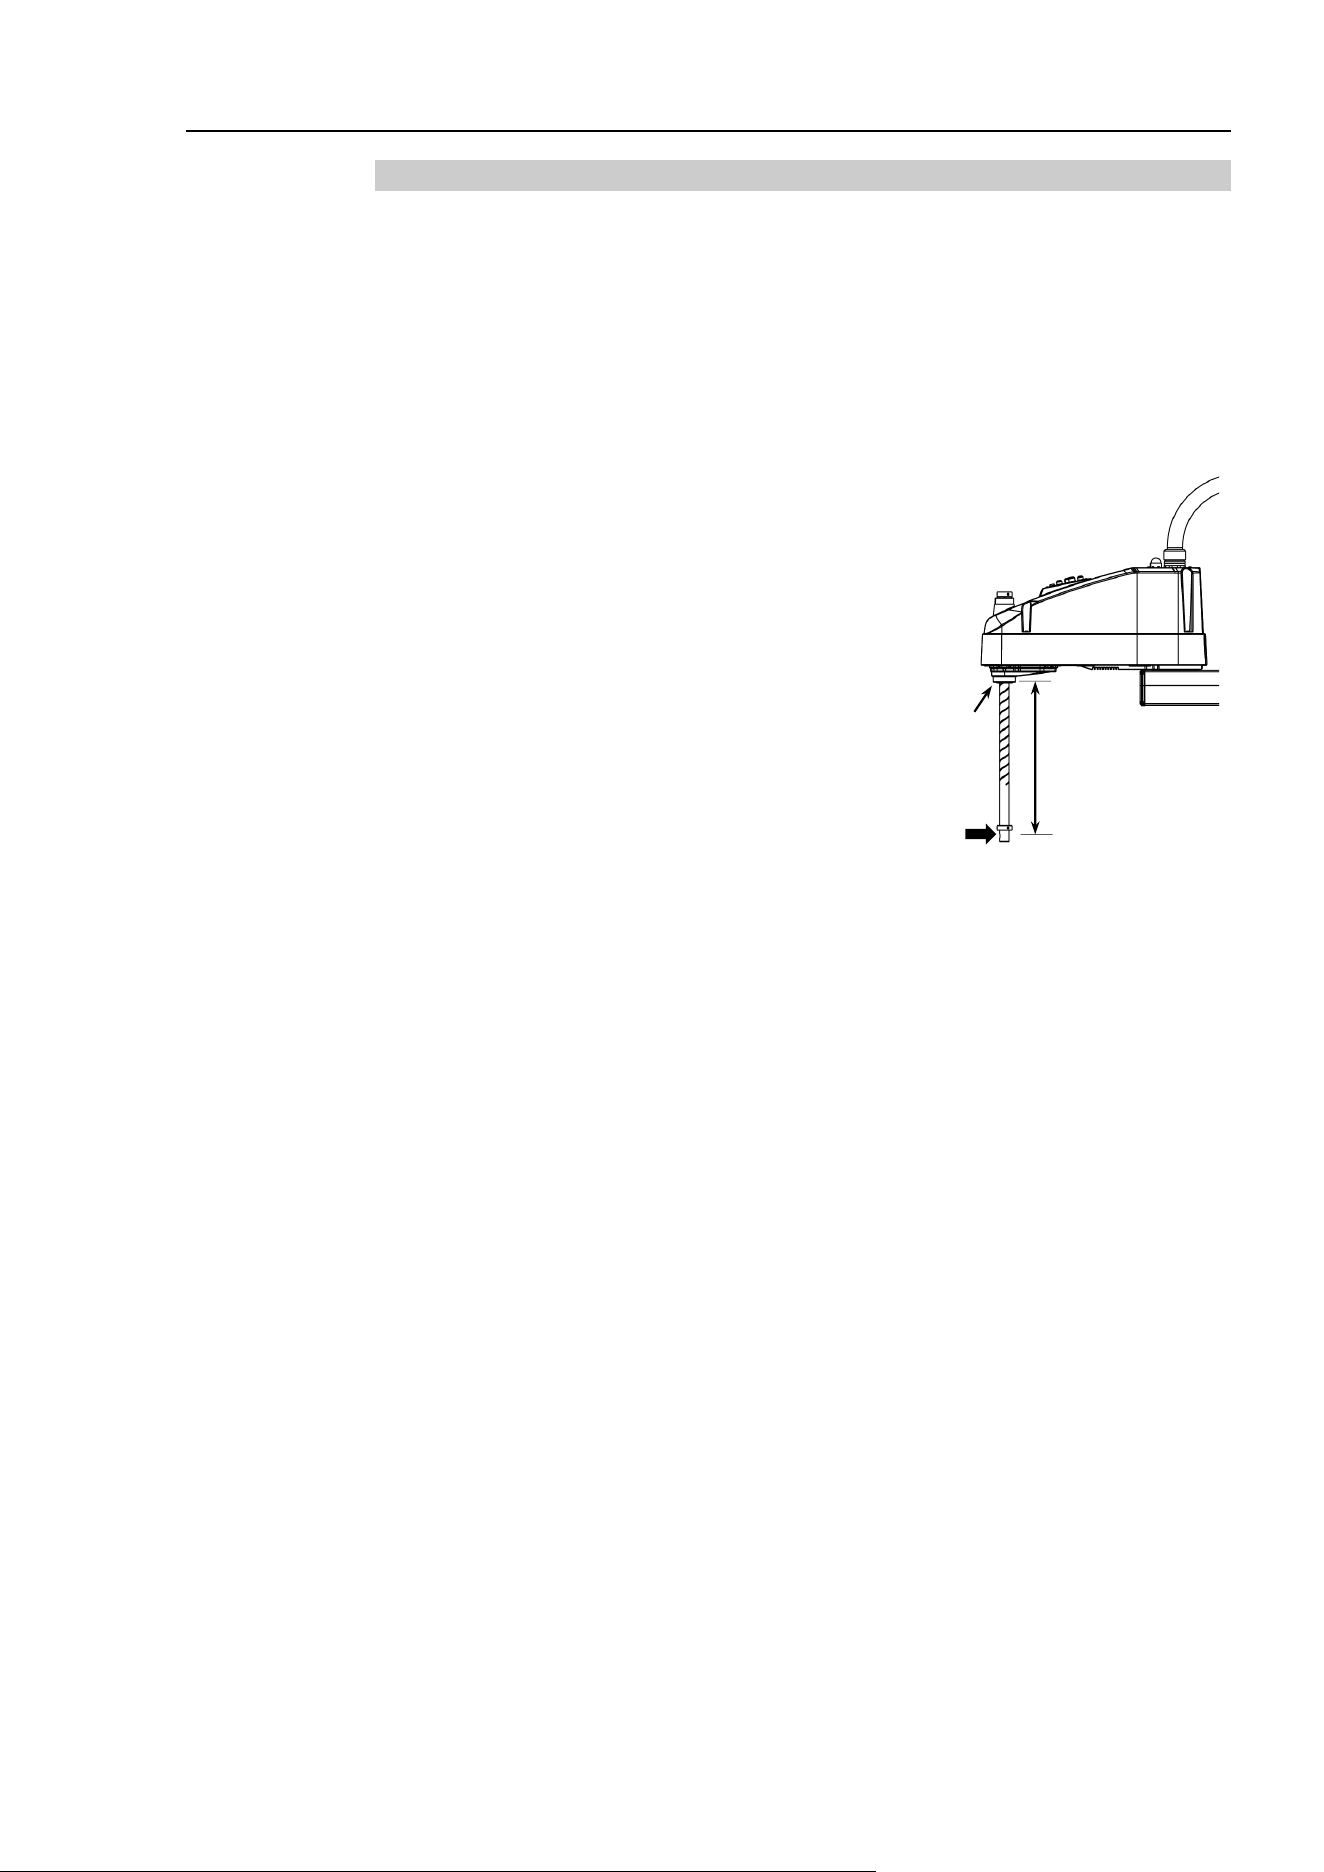
If a load exceeding the allowable value is applied to the ball screw spline, it may not work
properly due to deformation or breakage of the shaft.
If the ball screw spline is applied the load exceeding the allowable value, it is necessary to
replace the ball screw spline unit.
The allowable loads differ depending on distance where the load is applied to.
For calculating the allowable load, see the calculation formula below.
[Allowable bending moment]
M=50,000 N·mm
[Moment]
M=F
∙
L
=
110
∙
400
=
44,000 N
∙
mm
Example:
If 110 N(11.2kgf) load is applied
at 400 mm from
the end of the spline nut
End of the
spline nut
F
L
Setup & Operation 1. Safety
6
LS20-B Rev.4
1.3 Operation Safety
The following items are safety precautions for qualified Operator personnel:
WARNING
■
Please carefully read the
Safety-related Requirements in the Safety chapter of the
Safety and Installation
manual before operating the robot system. Operating the
robot system without understanding the safety requirements is extremely
hazardous and may result in serious bodily injury and/or sever
e equipment
damage to the robot system.
■
Do not enter the operating area of the Manipulator while the power to the robot
system is turned ON.
Entering the operating area with the power ON is extremely
hazardous and may cause serious safety problems as the Manipulator may move
even if it seems to
be stopped.
■
Before operating the robot system, make sure that no one is inside the
safeguarded area.
The robot system can be operated in the mode for teaching
even when someone is inside the safeguarded area.
The motion of the Manipulator is always i
n restricted (low speed and low power)
status to secure the safety of an operator.
However, operating the robot system
while someone is inside the safeguarded area
is extremely hazardous and may
result in serious safety problems in case that the Manipulator moves unexpectedly.
■
Immediately press the Emergency Stop switch whenever the Manipulator moves
abnormally while the robot system is operated.
Continuing the operation while
the Manipulator moves abnormally is extremely hazardous and may result in
serious bodily injury and/or severe equipment damage to the robot system.
W
ARNING
■
To shut off power
to the robot system, disconnect the power plug from the power
source. Be sure to connect the AC power cable to a power receptacle.
DO NOT connect it directly to a factory power source.
■
Before
performing any replacement procedure, turn OFF the Controller and
related equipment,
and then disconnect the power plug from the power source.
Performing any replacement procedure with the power ON is extremely hazardous
and may result in
electric shock and/or malfunction of the robot system.
■
Do not connect or disconnect the motor connectors while the power to the robot
system is turned ON. Connecting or disconnecting the motor connectors
with the
power ON is extremely hazardous and may result
in serious bodily injury as the
Manipulator may mo
ve abnormally, and also may result in electric shock and/or
malfunction of the robot system.
Setup & Operation 1. Safety
LS20-B Rev.4 7
CAUTION
■
Whenever possible, only one person should operate the robot system.
If it is
necessary to operate the robot system with more than one person, ensure that all
people involved communicate with each other as to what they are doing and take
all necessary safety precautions.
■
Joint #1, #2, and #4:
If the joints are operated
repeatedly with the operating angle less than 5 degrees,
they may get damaged early because the bearings are likely to cause oil film
shortage in such situation. To prevent early breakdown, move the joints larger
than 50 degrees
for about five to ten times a day.
Joint #3:
If the up
-and-down motion of the hand is less than 50 mm, move the joint a half of
the maximum stroke for five to ten times a day.
■
Vibration
(resonance) may occur continuously in low speed Manipulator motion
(Speed:
approx. 5 to 20%) depending on combination of Arm orientation and end
effector load.
Vibration arises from natural vibration frequency of the Arm and
can be controlled by following measures.
Changing Manipulator speed
Changing the teach points
Changing the end effector load
Setup & Operation 1. Safety
8
LS20-B Rev.4
1.4 Emergency Stop
If the Manipulator moves abnormally during operation, immediately press the Emergency
Stop switch. Stops the power supply to the motor, and the arm stops in the shortest distance
with the dynamic brake and mechanical brake.
Do not press the Emergency Stop switch unnecessarily while the Manipulator is operating.
Pressing the switch during the operation makes the brakes work. This will shorten the life
of the brakes due to the worn friction plates.
Normal brake life: About 2 years (when the brakes are used 100 times/day)
To place the system in emergency mode during normal operation, press the Emergency Stop
switch when the Manipulator is not moving. Refer to the Controller manual for
instructions on how to wire the Emergency Stop switch circuit.
Do not turn OFF the Controller while the Manipulator is operating.
If you attempt to stop the Manipulator in emergency situations such as “Safeguard Open”,
make sure to stop the Manipulator using the Emergency Stop switch of the Controller.
If the Manipulator is stopped by turning OFF the Controller while it is operating, following
problems may occur:
Reduction of the life and damage of the reduction gear unit
Position gap at the joints
In addition, if the Controller was forced to be turned OFF by blackouts and the like while
the Manipulator is operating, make sure to check the following points after power
restoration:
Whether or not the reduction gear is damaged
Whether or not the joints are in their proper positions
If there is a position gap, perform calibration by referring to the Maintenance 13.
Calibration in this manual.
Before using the Emergency Stop switch, be aware of the followings:
- The Emergency Stop (E-STOP) switch should be used to stop the Manipulator only in
case of emergencies.
- To stop the Manipulator operating the program except in emergency, use Pause (halt)
or STOP (program stop) commands.
Pause and STOP commands do not turn OFF the motors. Therefore, the brake does
not function.
- For the Safeguard system, do not use the circuit for E-STOP.
For details on the Safeguard system, refer to the following manuals.
EPSON RC+ User’s Guide
2. Safety - Installation and Design Precautions - Safeguard System
Safety and Installation
2.6 Connection to EMERGENCY Connector
To check brake problems, refer to the following manuals.
Manipulator Manual Maintenance
2.1.2 Inspection Point - Inspection While the Power is ON
(Manipulator is operating)
Safety and Installation
5.1.1 Manipulator
- Inspection While the Power is ON (Manipulator is operating)
Setup & Operation 1. Safety
LS20-B Rev.4 9
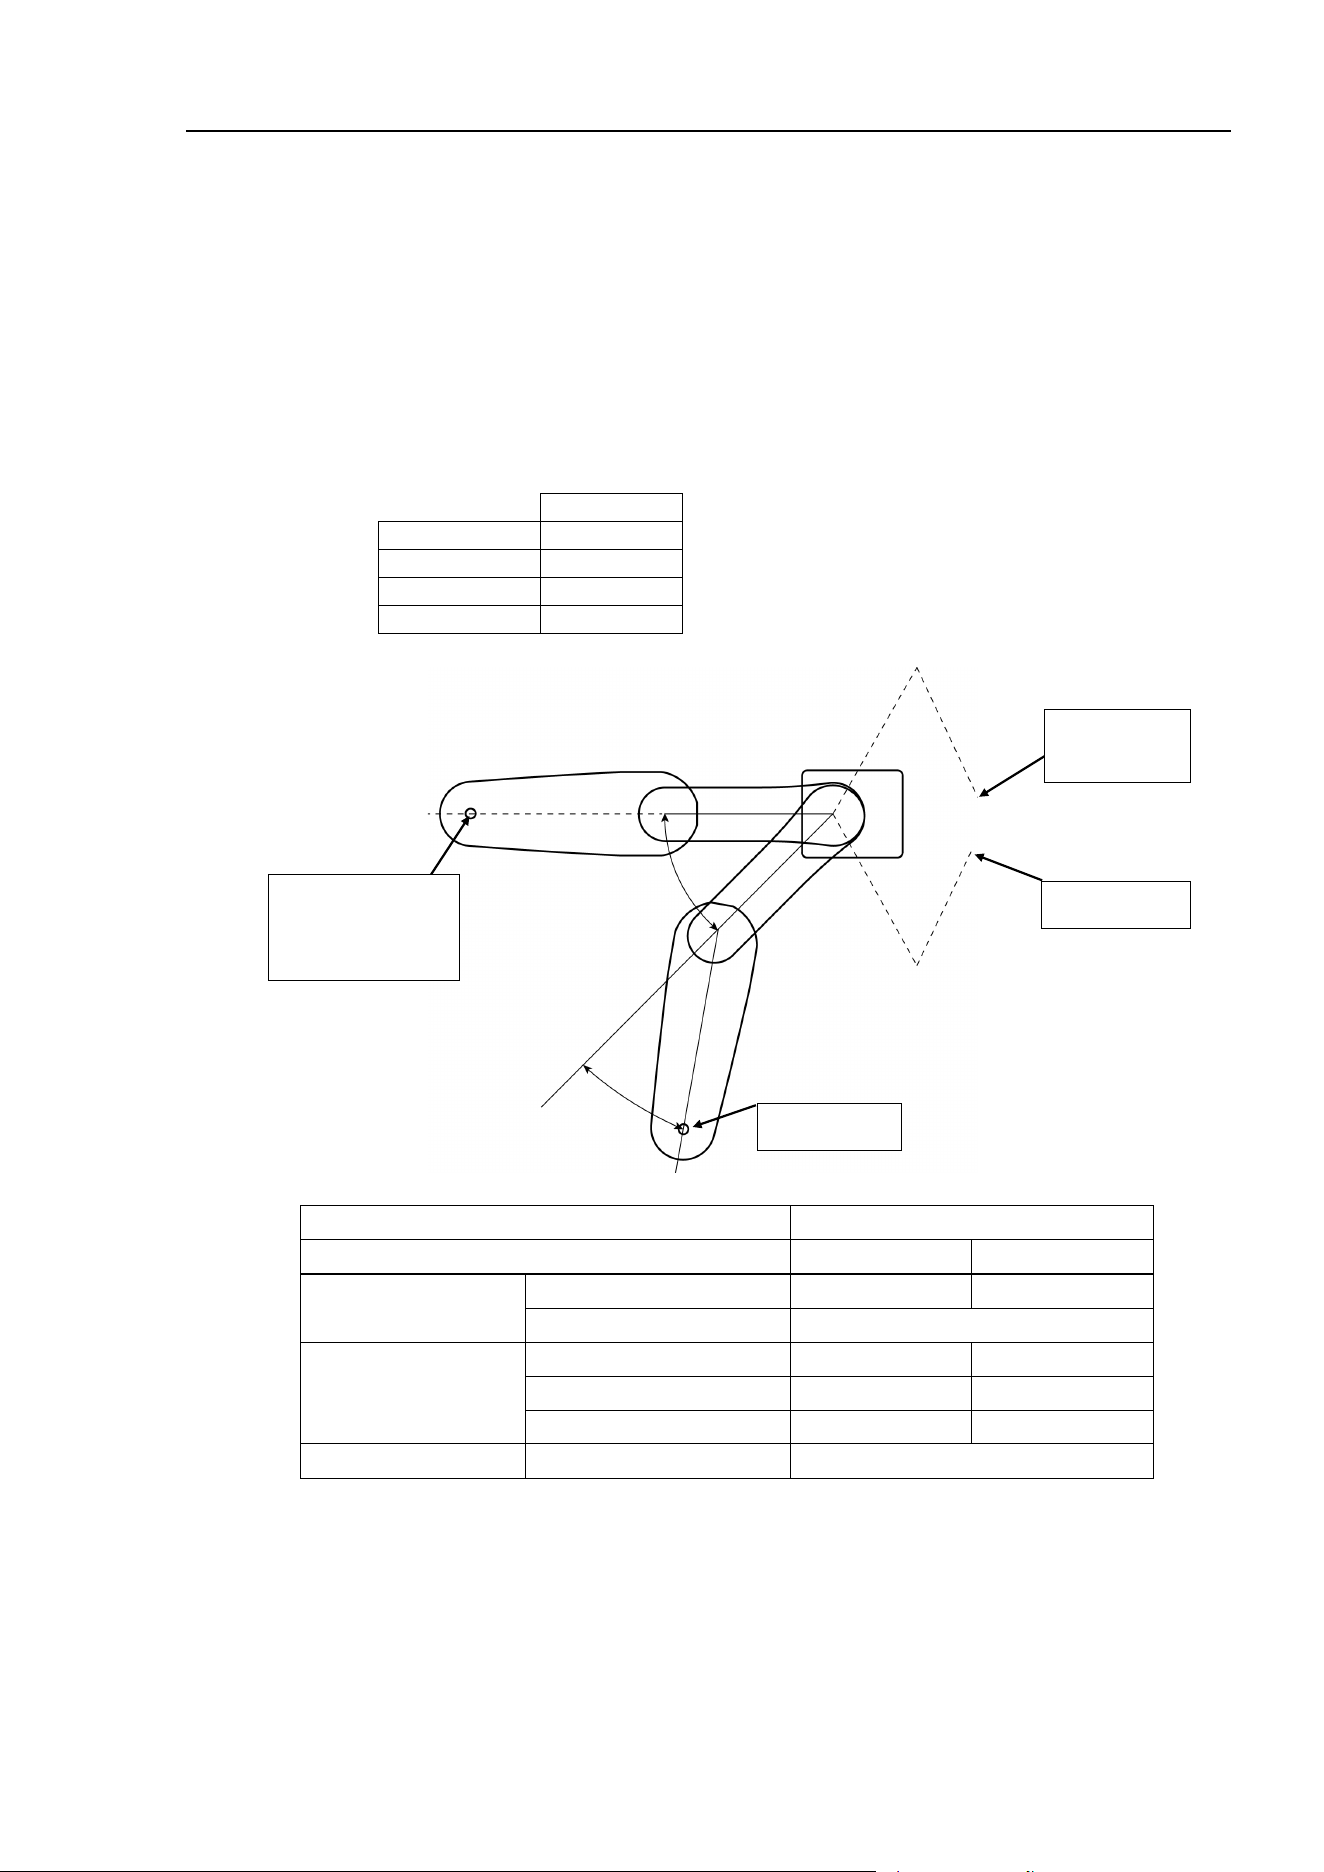
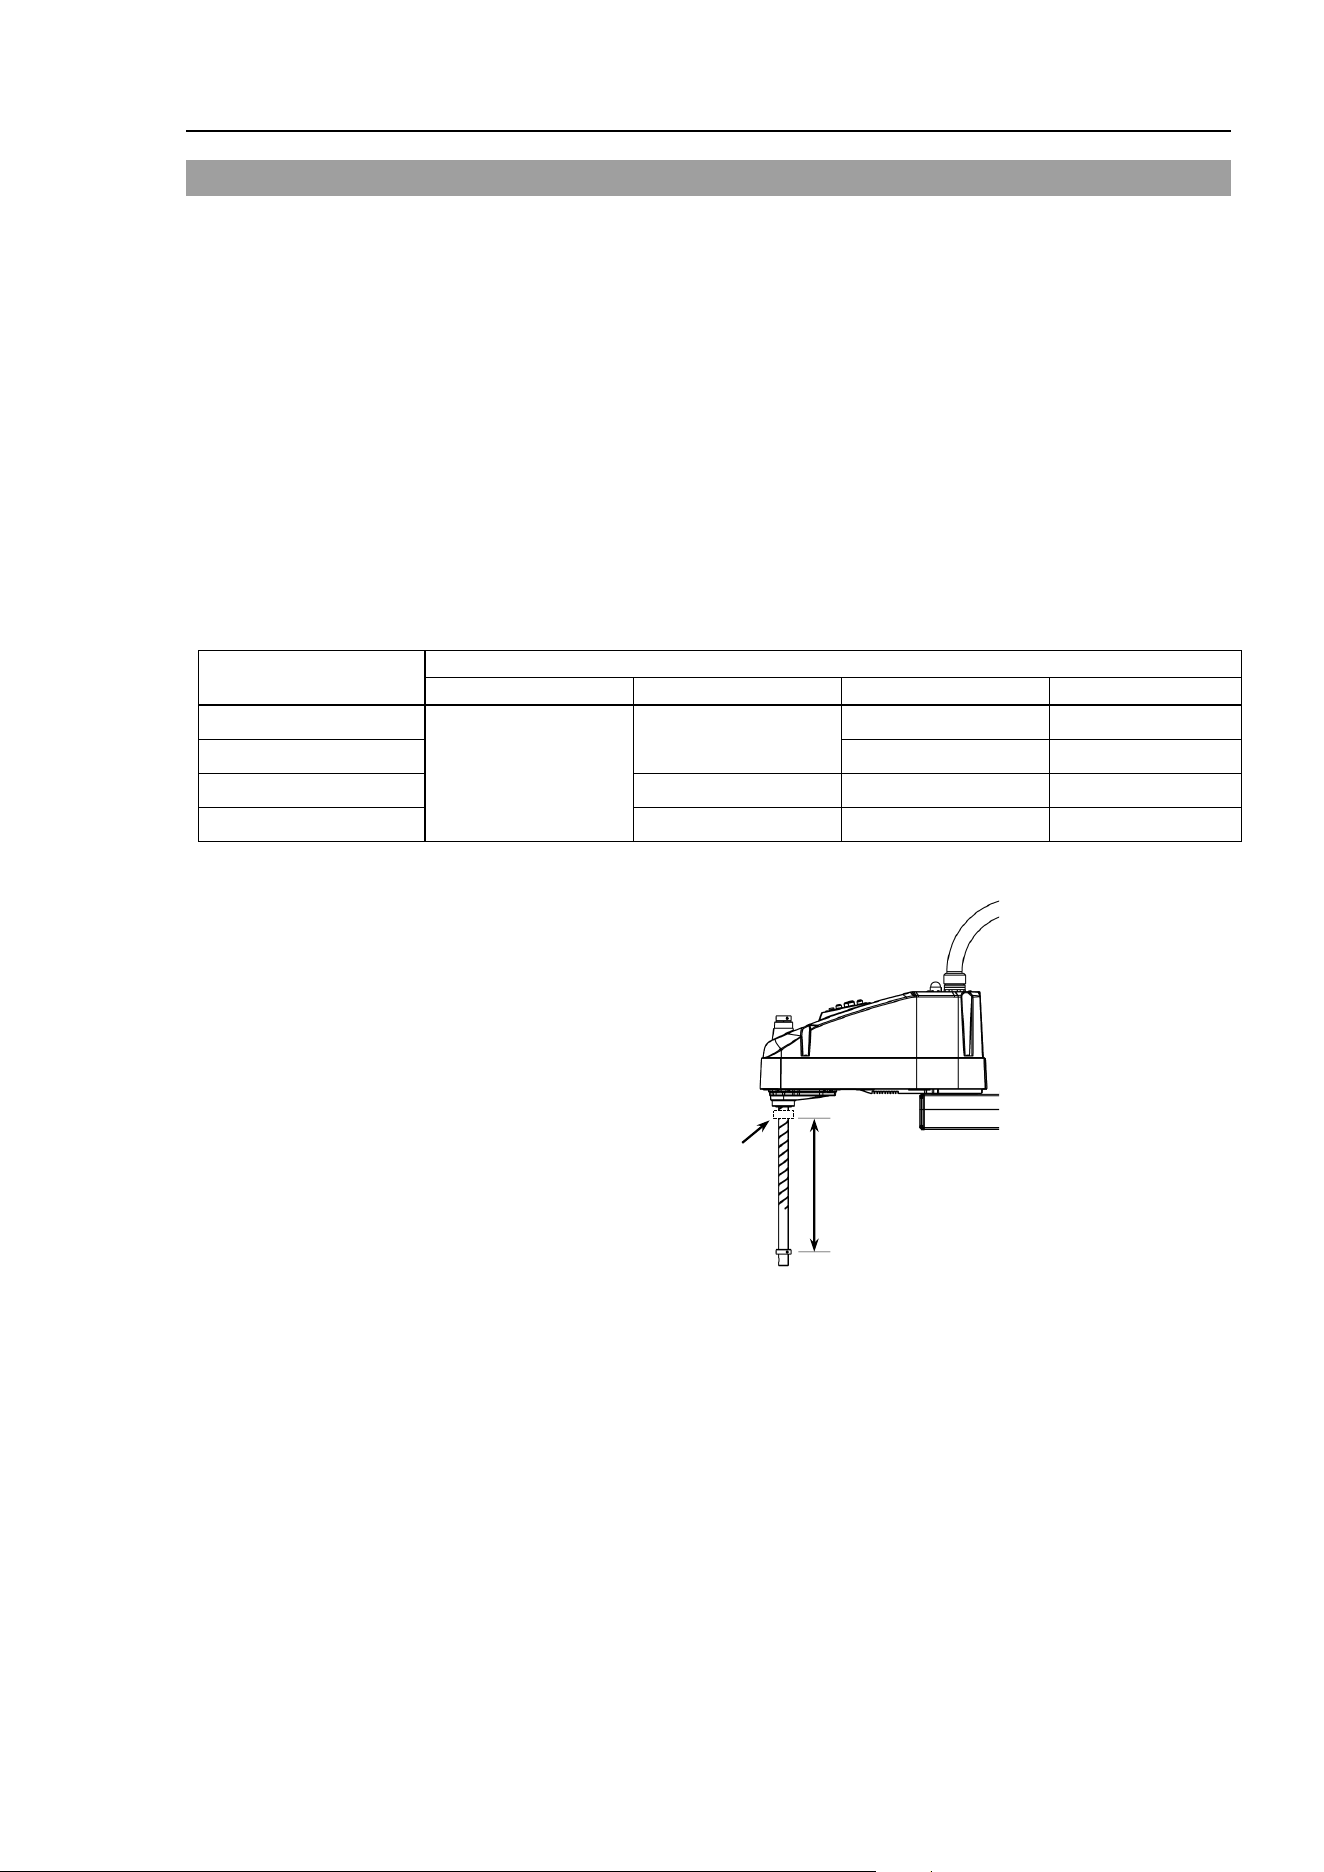
Free running distance in emergency
The operating Manipulator cannot stop immediately after the Emergency Stop switch is
pressed.
The free running time/angle/distance of the Manipulator are shown below.
However, remember that the values vary depending on following conditions.
Weight of the end effector Weight setting
Weight of work piece Speed setting
Operating pose Accel setting
Conditions for Measurement
LS20-B**4*
Accel Setting
100
Speed Setting
100
Load [kg]
20
Weight Setting
20
Joint #1
Stop point
Point where the
emergency stop
signal is input
Target point
Start point of
operation
Joint #2
Controller RC90-B
Manipulator LS20-B804* LS20-BA04*
Free running time
Joint #1 + Joint #2 [sec.] 0.60 0.65
Joint #3 [sec.] 0.3
Free running angle
Joint #1 [°] 65 85
Joint #2 [°] 63 55
Joint #1 + Joint #2 [°] 120 125
Free running distance Joint #3 [mm] 50
Setup & Operation 1. Safety
10
LS20-B Rev.4
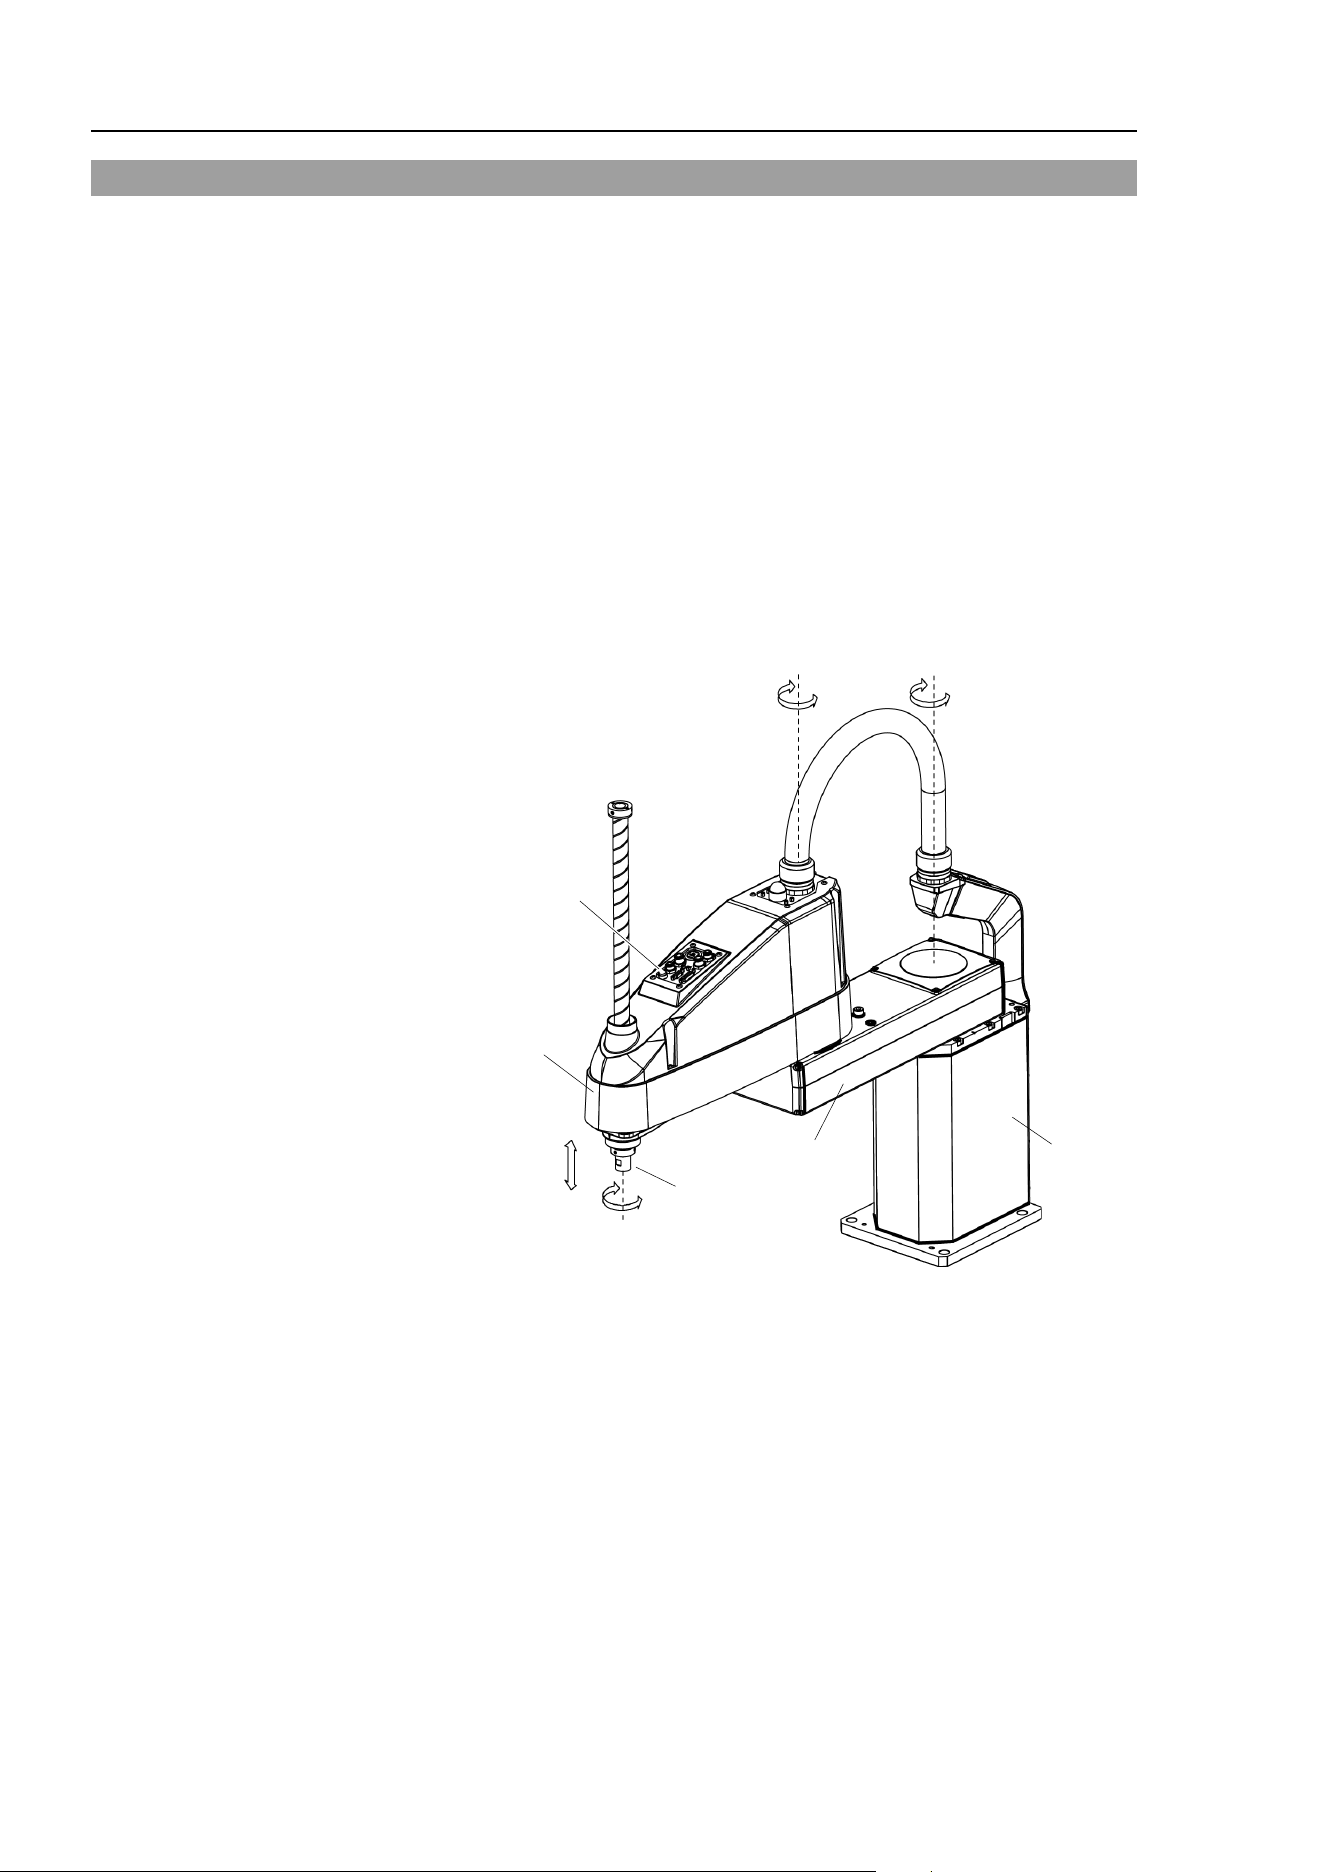
1.5 Emergency Movement without Drive Power
When the system is placed in emergency mode, push the arm or joint of the Manipulator by
hand as shown below:
Arm #1 Push the arm by hand.
Arm #2 Push the arm by hand.
Joint #3 The joint cannot be moved up/down by hand until the
electromagnetic brake applied to the joint has been released. Move
the joint up/down while pressing the brake release switch.
Joint #4 The shaft cannot be rotated by hand until the electromagnetic brake
applied to the shaft has been released. Move the shaft while
pressing the brake release switch.
Brake release switch
Joint #1
(rotating)
Joint #2
(rotating)
Joint #3
(up and down)
Joint #4
(rotating)
Arm #1
Arm #2
+
−
+
−
+
−
+
−
Shaft
(Figure: LS20-B804S)
Base
T
he brake release switch affects both Joints #3 and #4. When the brake release switch is
pressed in emergency mode, the brake for both Joints #3 and #4 are released simultaneously.
Be careful of the shaft falling and rotating while the brake release switch is pressed because
the shaft may be lowered by the weight of an end effector.
NOTE
Setup & Operation 1. Safety
LS20-B Rev.4 11
1.6 ACCELS Setting for CP Motions
When operating the Manipulator in CP motion:
Acceleration/deceleration may be adjusted automatically depending on the tip load and
the Z-axis height to prevent damages of the ball screw spline.
ACCELS correction is performed by WEIGHT setting. If the Weight setting is not proper
for the tip load, the following problem occurs.
- Decline in the life and damage of the ball screw spline
Example:
Maximum value of ACCELS is corrected automatically depending on the Z-axis height.
The following is an example of values which are corrected per 100mm (Z-axis height).
Maximum ACCELS correction values by Z-axis height and tip load
Z-axis height
(mm)
Tip load
5kg or less
10kg or less
15kg or less
20kg or less
0 > Z >=
−
100
10000 or less
10000 or less
10000 or less
9000 or less
−
100 > Z >=
−
200
7000 or less
5500 or less
−
200 > Z >=
−
300
7500 or less
5000 or less
3500 or less
−
300 > Z >=
−
420
5500 or less
3500 or less
2500 or less
Z-axis height 0
(Origin position)
Z
If the Manipulator is operated in CP motion with the wrong set values, make sure to check
the following.
- Whether or not the ball screw spline shaft is deformed or bent
NOTE
Setup & Operation 1. Safety
12
LS20-B Rev.4
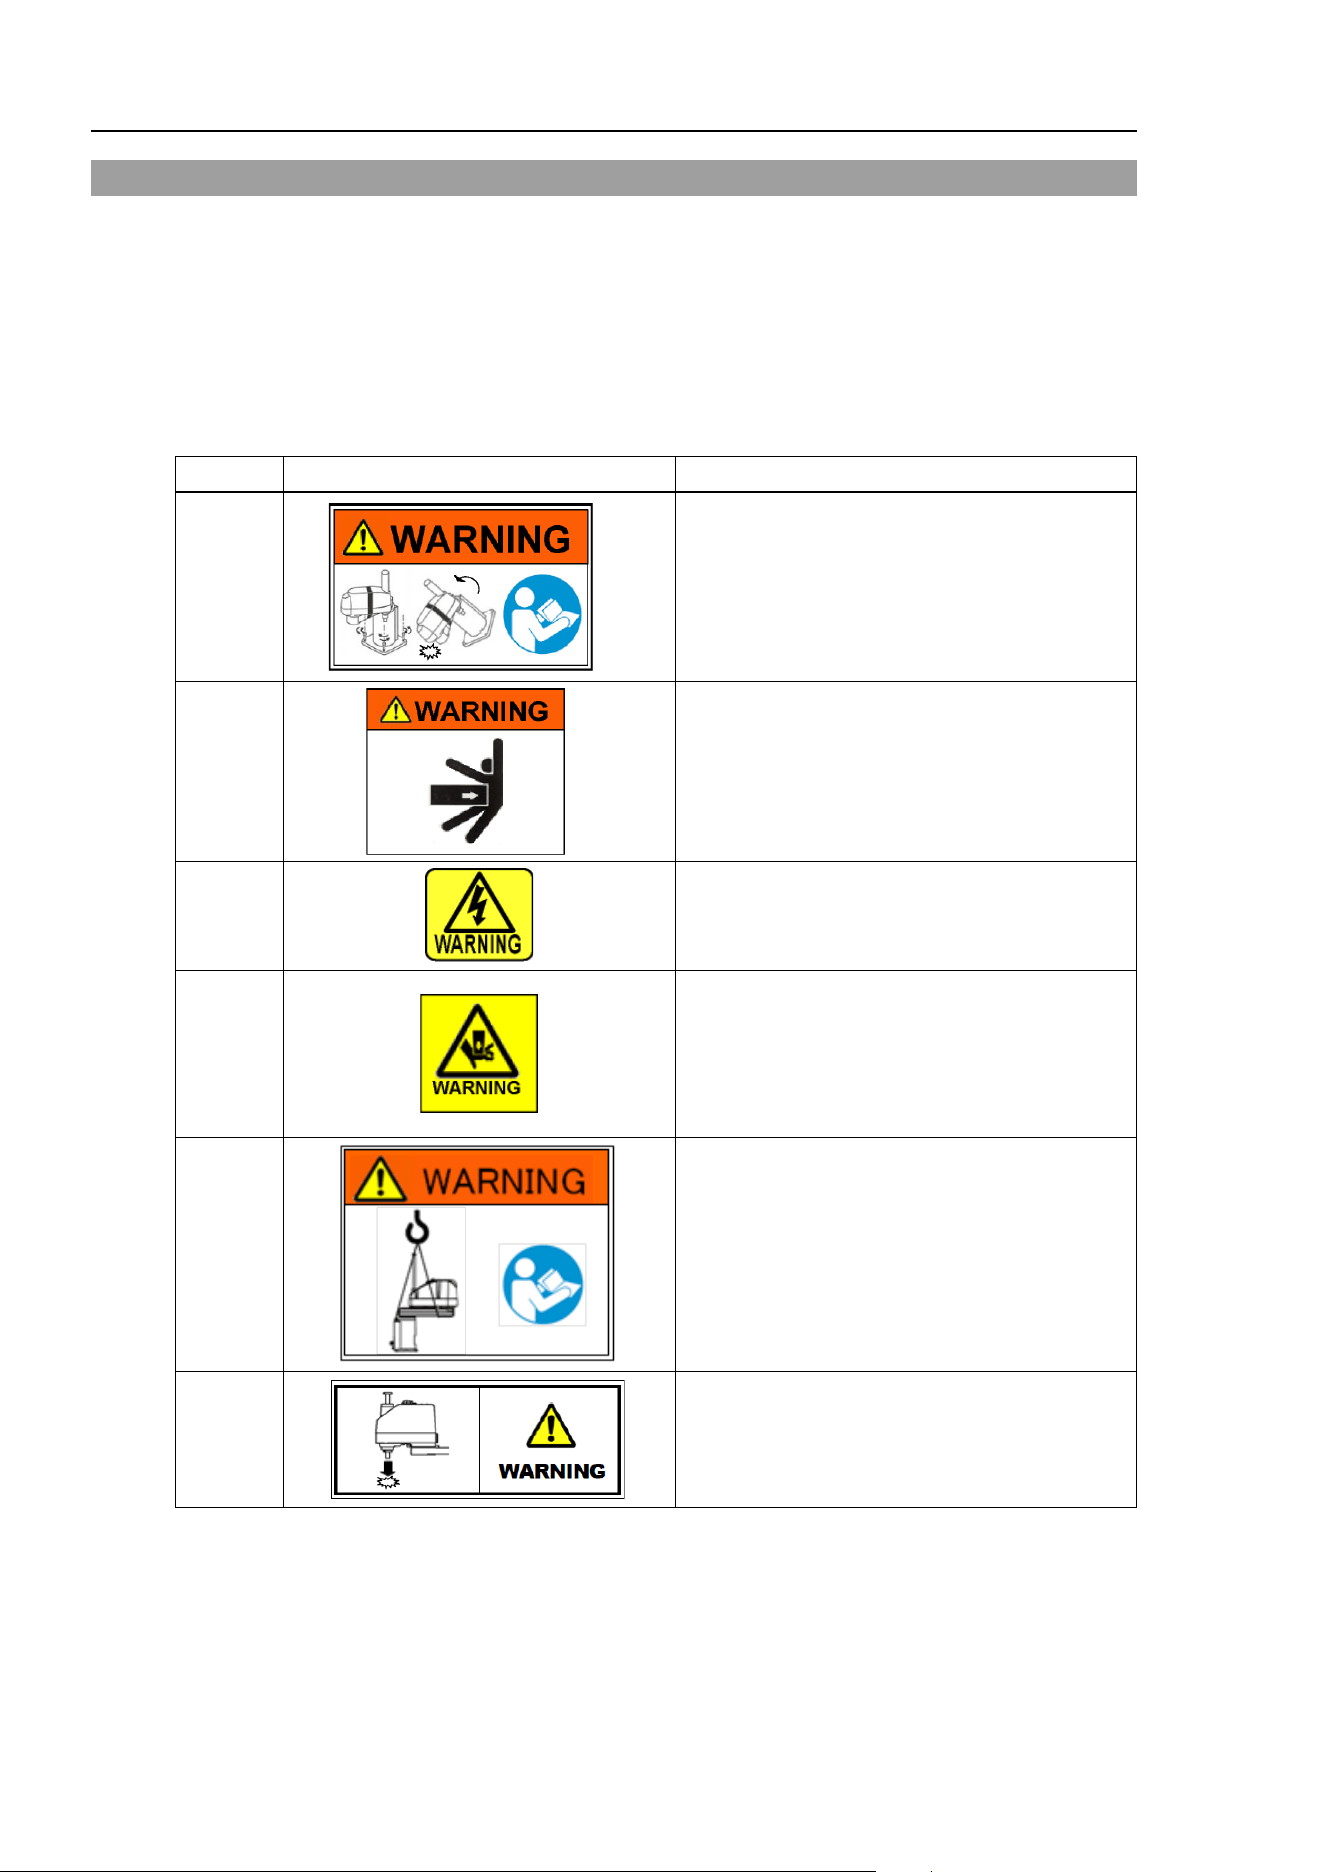
1.7 Warning Labels
The Manipulator has the following warning labels.
The warning labels are attached around the locations where specific dangers exist.
Be sure to comply with descriptions and warnings on the labels to operate and maintain the
Manipulator safely.
Do not tear, damage, or remove the warning labels. Use meticulous care when handling
those parts or units to which the following warning labels are attached as well as the nearby
areas.
Location Warning Label NOTE
A
Before loosening the base mounting screws,
hold the arm and secure it tightly with a band to
prevent hands or fingers from being caught in the
Manipulator.
B
Do not enter the operation area while the
Manipulator is moving. The robot arm may
collide against the operator. This is extremely
hazardous and may result in serious safety
problems.
C
Hazardous voltage exists while the Manipulator
is ON. To avoid electric shock, do not touch any
internal electric parts.
D
You can catch your hand or fingers between the
shaft and cover when bringing your hand close to
moving parts.
* Manipulators with bellows do not have this label
for no danger of your hand or fingers being
caught.
E
Only authorized personnel should perform sling
work and operate a crane and a forklift.
When these operations are performed by
unauthorized personnel, it is extremely
hazardous and may result in serious bodily injury
and/or severe equipment damage to the robot
system.
F
Be careful of the shaft falling and rotating while
the brake release switch is pressed because the
shaft may be lowered by the weight of the end
effector.
Setup & Operation 1. Safety
LS20-B Rev.4 13
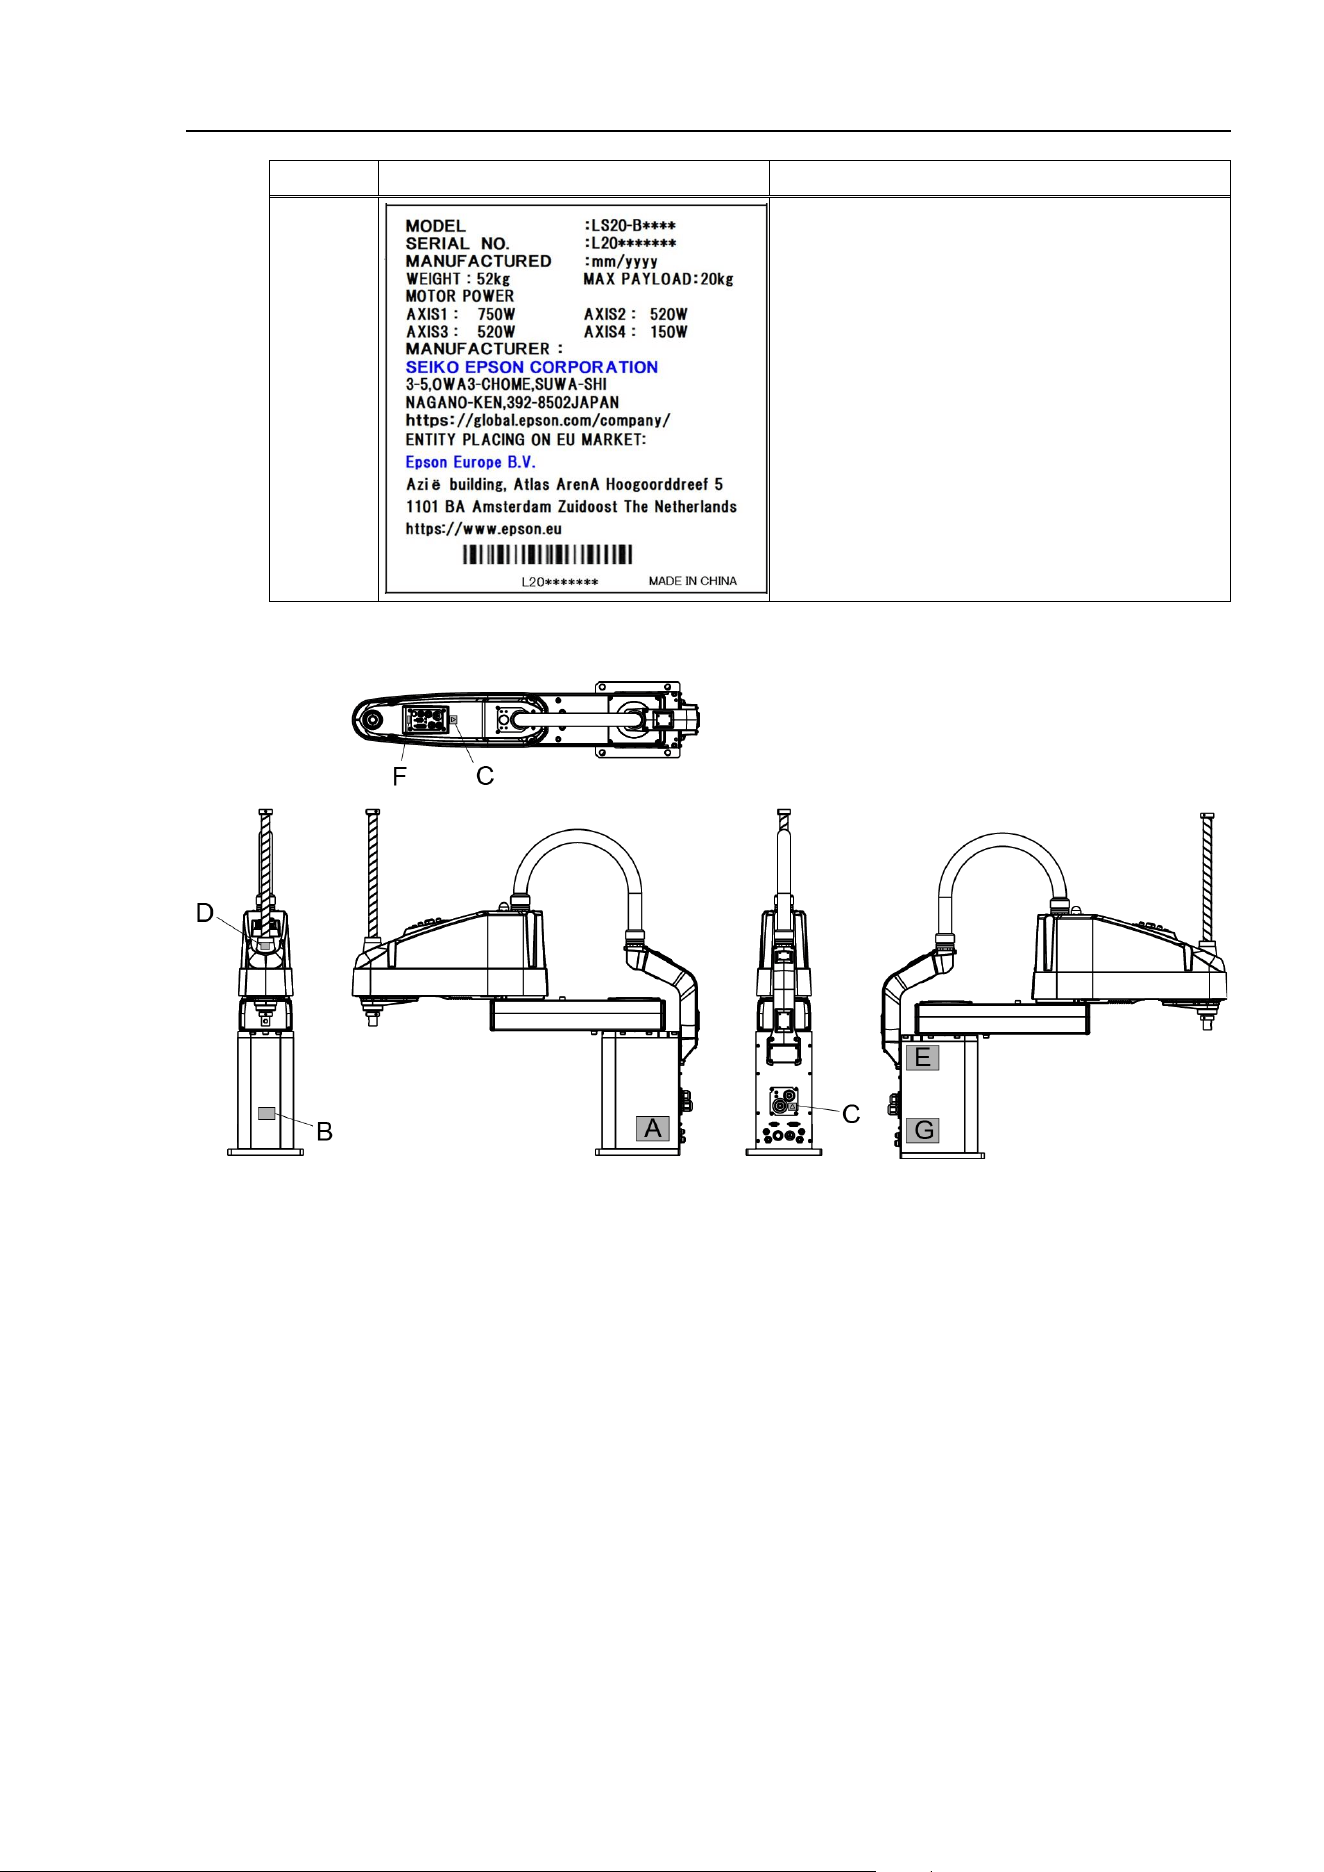
Location Signature label NOTE
G
Manipulator’s serial No.
LS20-B
(Figure: LS20-B804S)
Setup & Operation 2. Specifications
14
LS20-B Rev.4
2. Specifications
2.1 Features of LS20-B series Manipulators
The LS20-B series Manipulators are advanced manipulators pursuing high speed and high
cost-performance. The features of the LS20-B series Manipulators are as follows:
Large capacity
It improves the U-axis allowable moment up to 1.00 kg·m
2
.
Handle large loads stably by optimized control based on the each load.
Tact time improvement by high-speed motion
It improves the tact time of delicate movements by acceleration/deceleration speed
optimized for each payload and stop short technology.
Ethernet connector for camera cable is equipped by default
Ethernet connector is equipped on Arm #2 and base of the manipulator by default.
Easier to equip a camera (option: Vision Guide) than the conventional models.
Simplify the connection and disconnection of M/C cable
Connect the M/C cable and the cable inside the manipulator with the connector.
Easy to connect and disconnect the M/C cable and easier to transport the manipulator
than the conventional models.
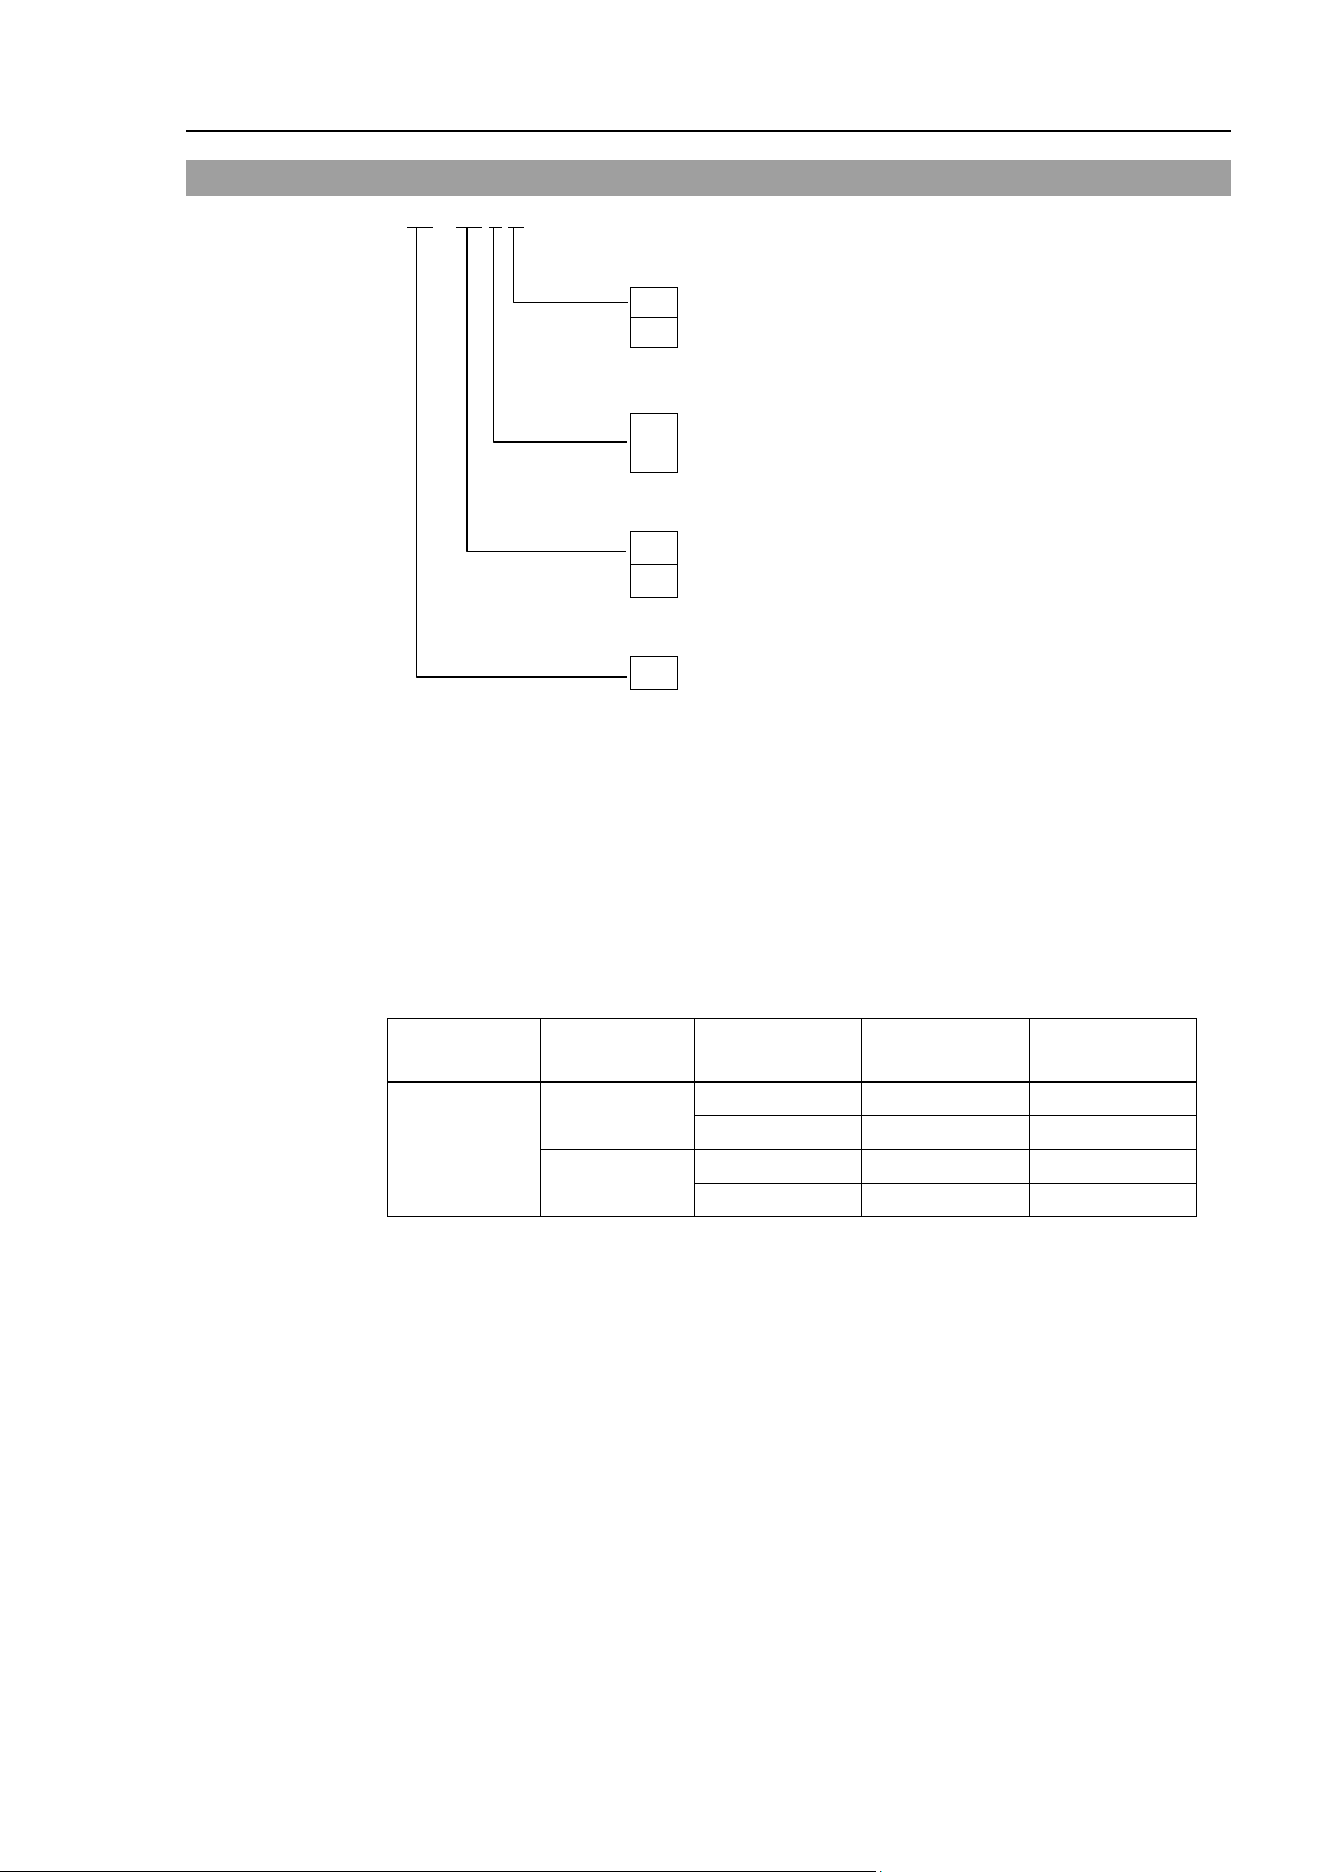
Setup & Operation 2. Specifications
LS20-B Rev.4 15
2.2 Model Number
LS20-B80 4 S
Environment
S
: Standard
C
: Cleanroom
Joint #3 stroke
4
: 420 mm : Standard-Model
: 390 mm : Cleanroom-Model (with bellows)
Arm length
80
: 800 mm
A0 : 1000 mm
Payload
20 : 20 kg
Environment
Cleanroom-model
This model has additional features that reduce dust emitted by the Manipulator to
enable use in clean room environments.
For details on the specifications, refer to Setup & Operation: 2.4 Specifications.
Models
Payload Arm length Environment
Joint #3
stroke
Model
Number
20 kg
800 mm
Standard
420 mm
LS20-B804S
Cleanroom
390 mm
LS20-B804C
1000 mm
Standard
420 mm
LS20-BA04S
Cleanroom
390 mm
LS20-BA04C
Setup & Operation 2. Specifications
16
LS20-B Rev.4
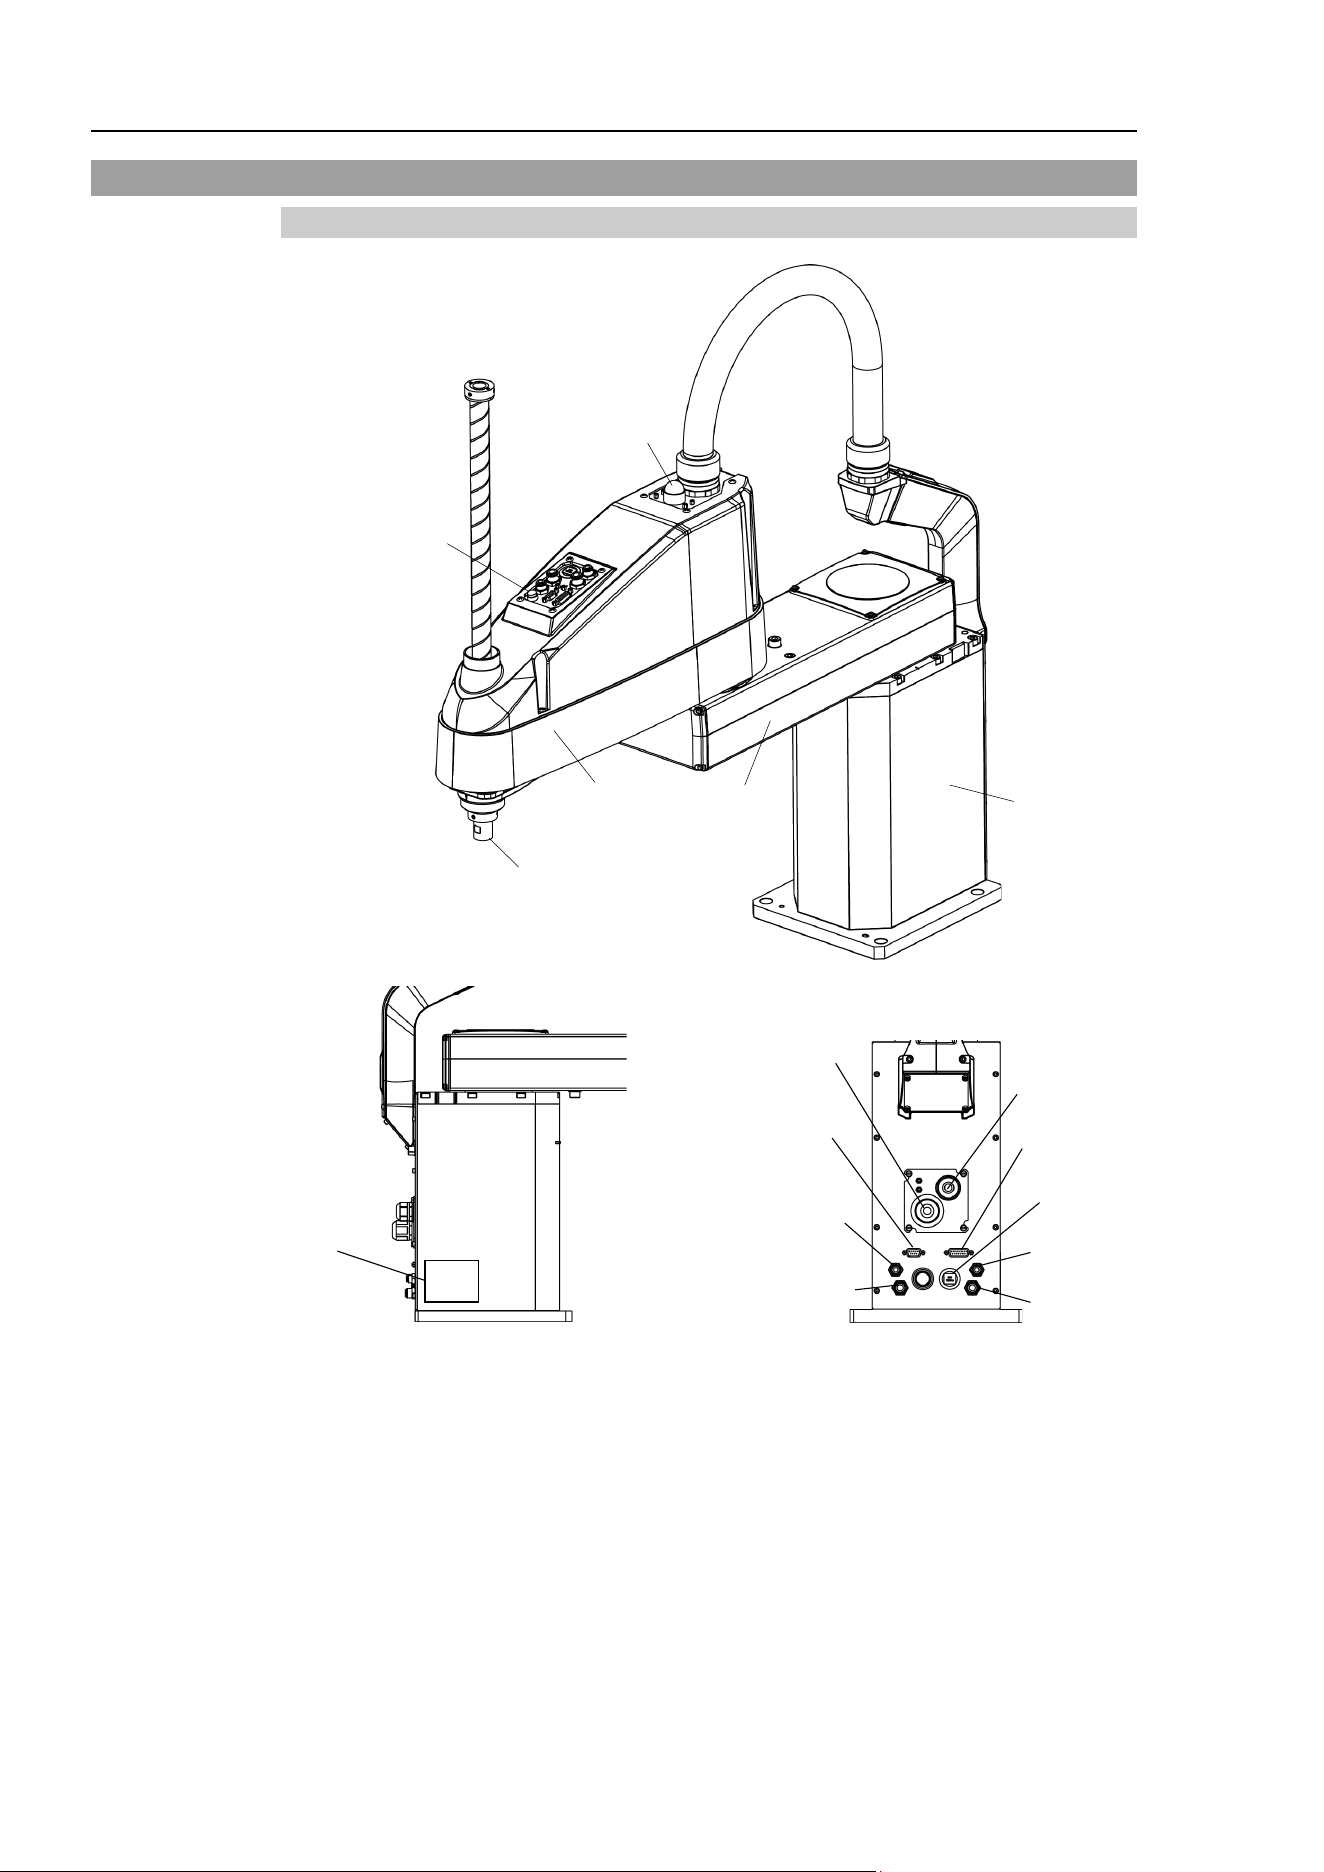
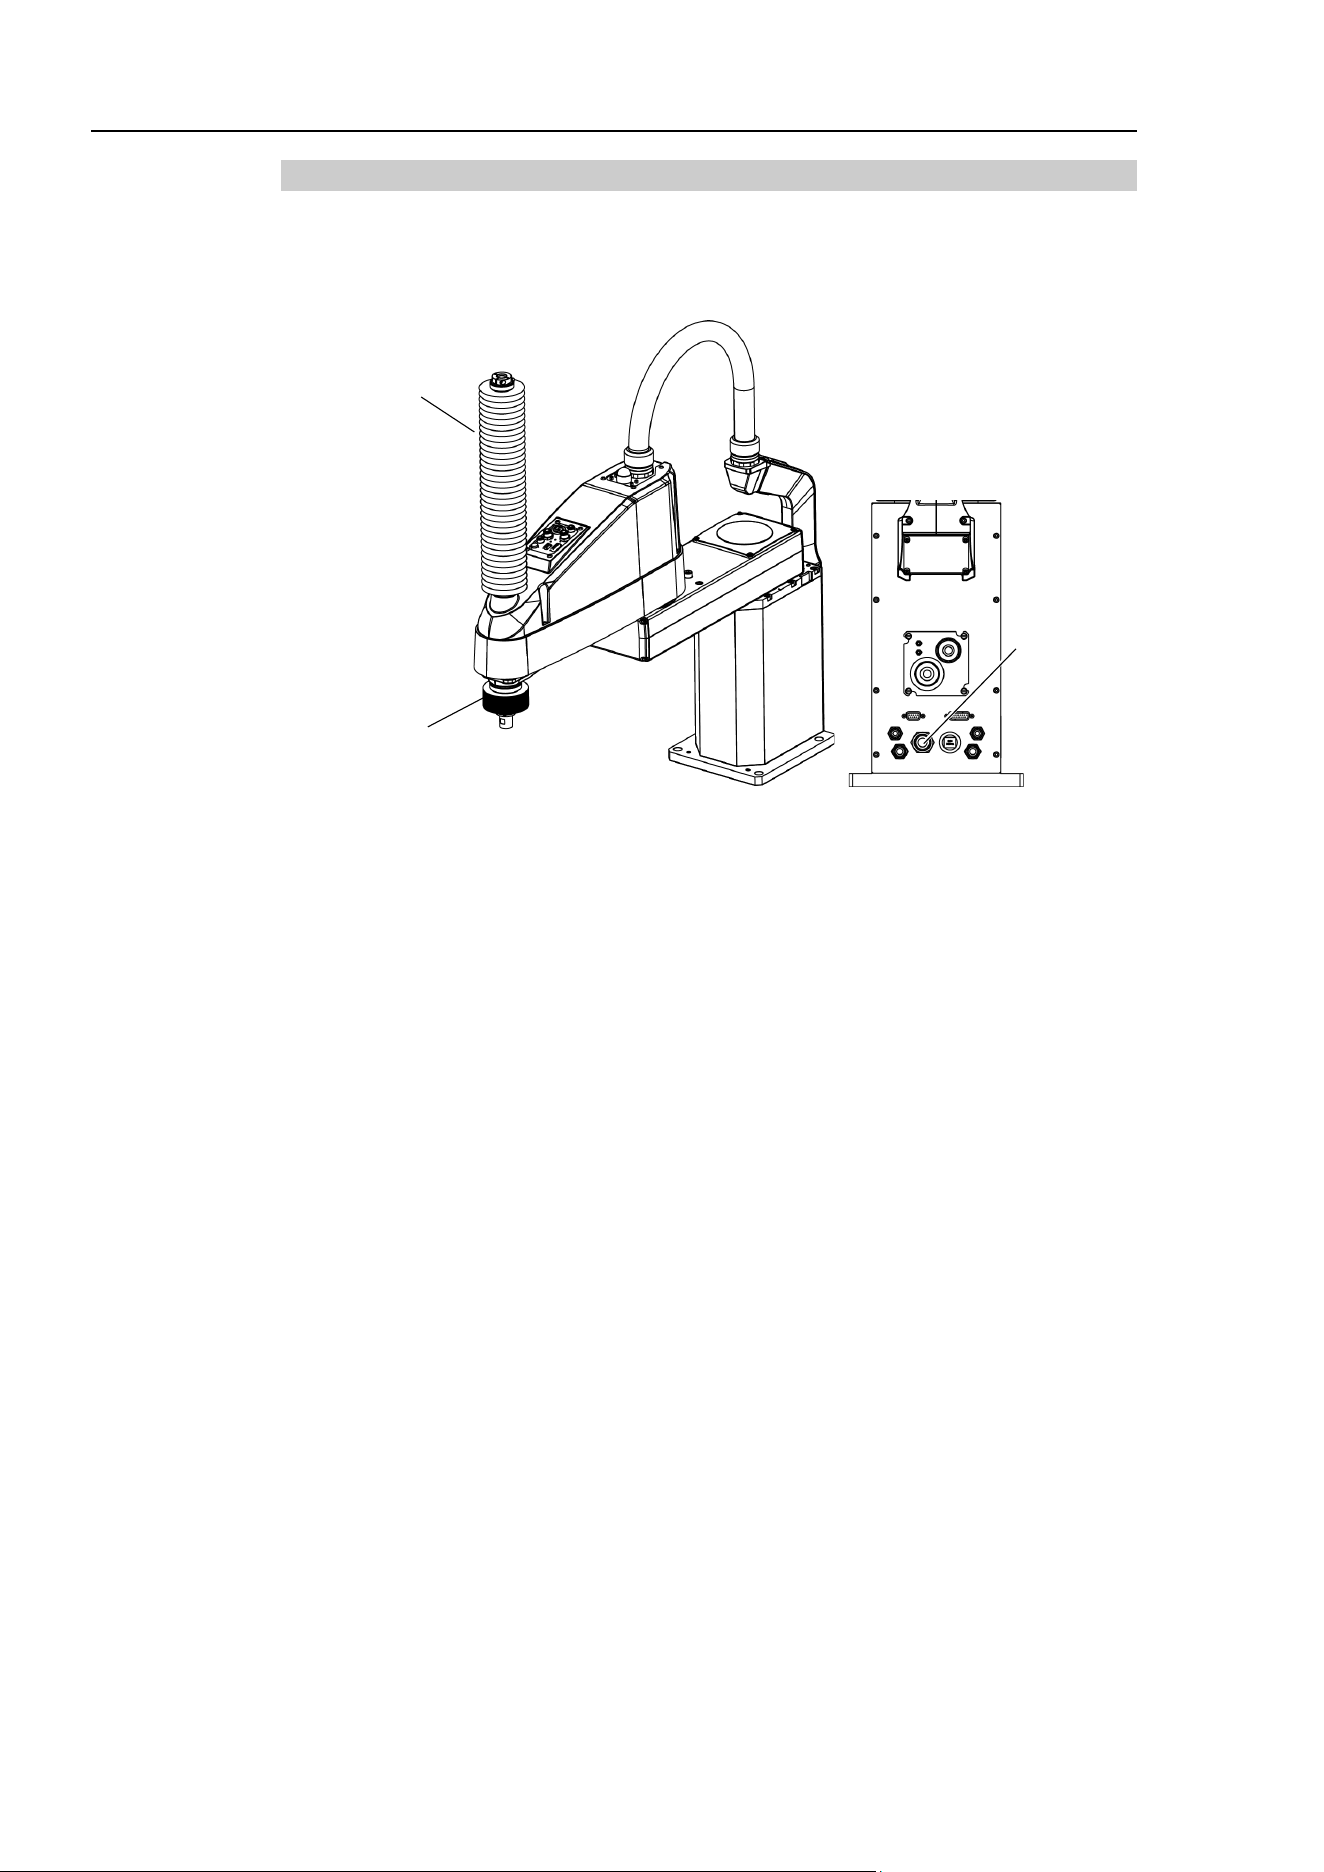
2.3 Part Names and Outer Dimensions
2.3.1 Standard-Model (LS20-B**4S)
Brake release switch
Arm #1
Arm #2
Base
Shaft
LED lamp
Signature label
(Serial No.
of Manipulator)
Power cable
Fittings for ø8 mm
pneumatic tube (No. 3)
Fittings for ø8 mm
pneumatic tube (No. 2)
User connector
(15-pin
D-sub connector)
Ethernet connector
Fittings for ø6 mm
pneumatic tube (No. 1)
Signal cable
Fittings for ø6 mm
pneumatic tube (No. 4)
User connector
(9-pin D-sub connector)
- T
he brake release switch affects both Joints #3 and #4. When the brake release switch
is pressed in emergency mode, the brakes for both Joint #3 and Joint #4 are release
d
s
imultaneously.
- While the LED lamp is on, current is being applied to the manipulator. Performing any
work with the power ON is extremely hazardous and it may result in electric shock and/or
improper function of the robot system. Make sure to turn OFF the controller power
before the maintenance work.
NOTE
Setup & Operation 2. Specifications
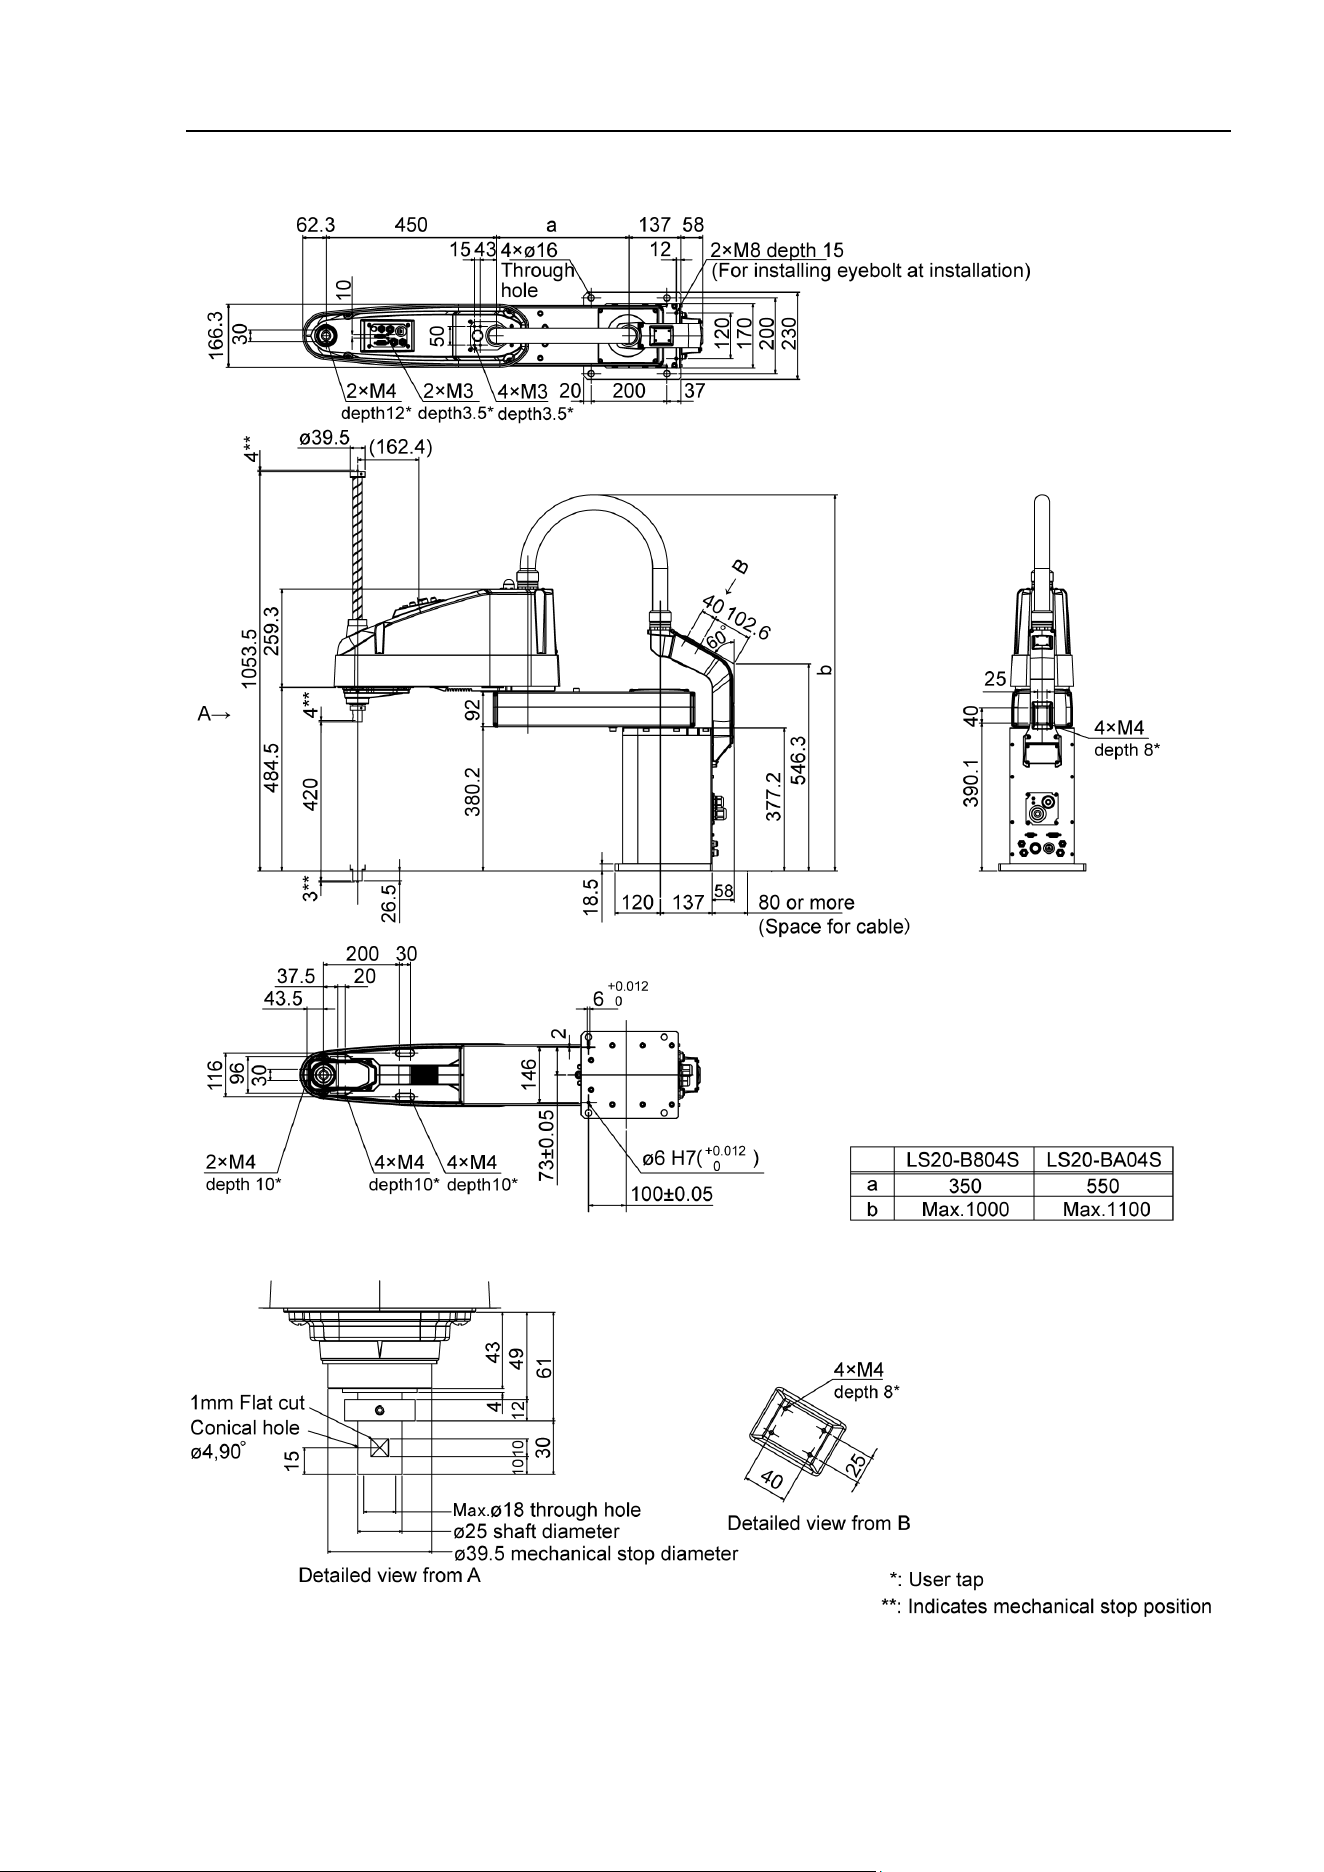
LS20-B Rev.4 17
Standard-Model (LS20-B**4S)
Setup & Operation 2. Specifications
18
LS20-B Rev.4
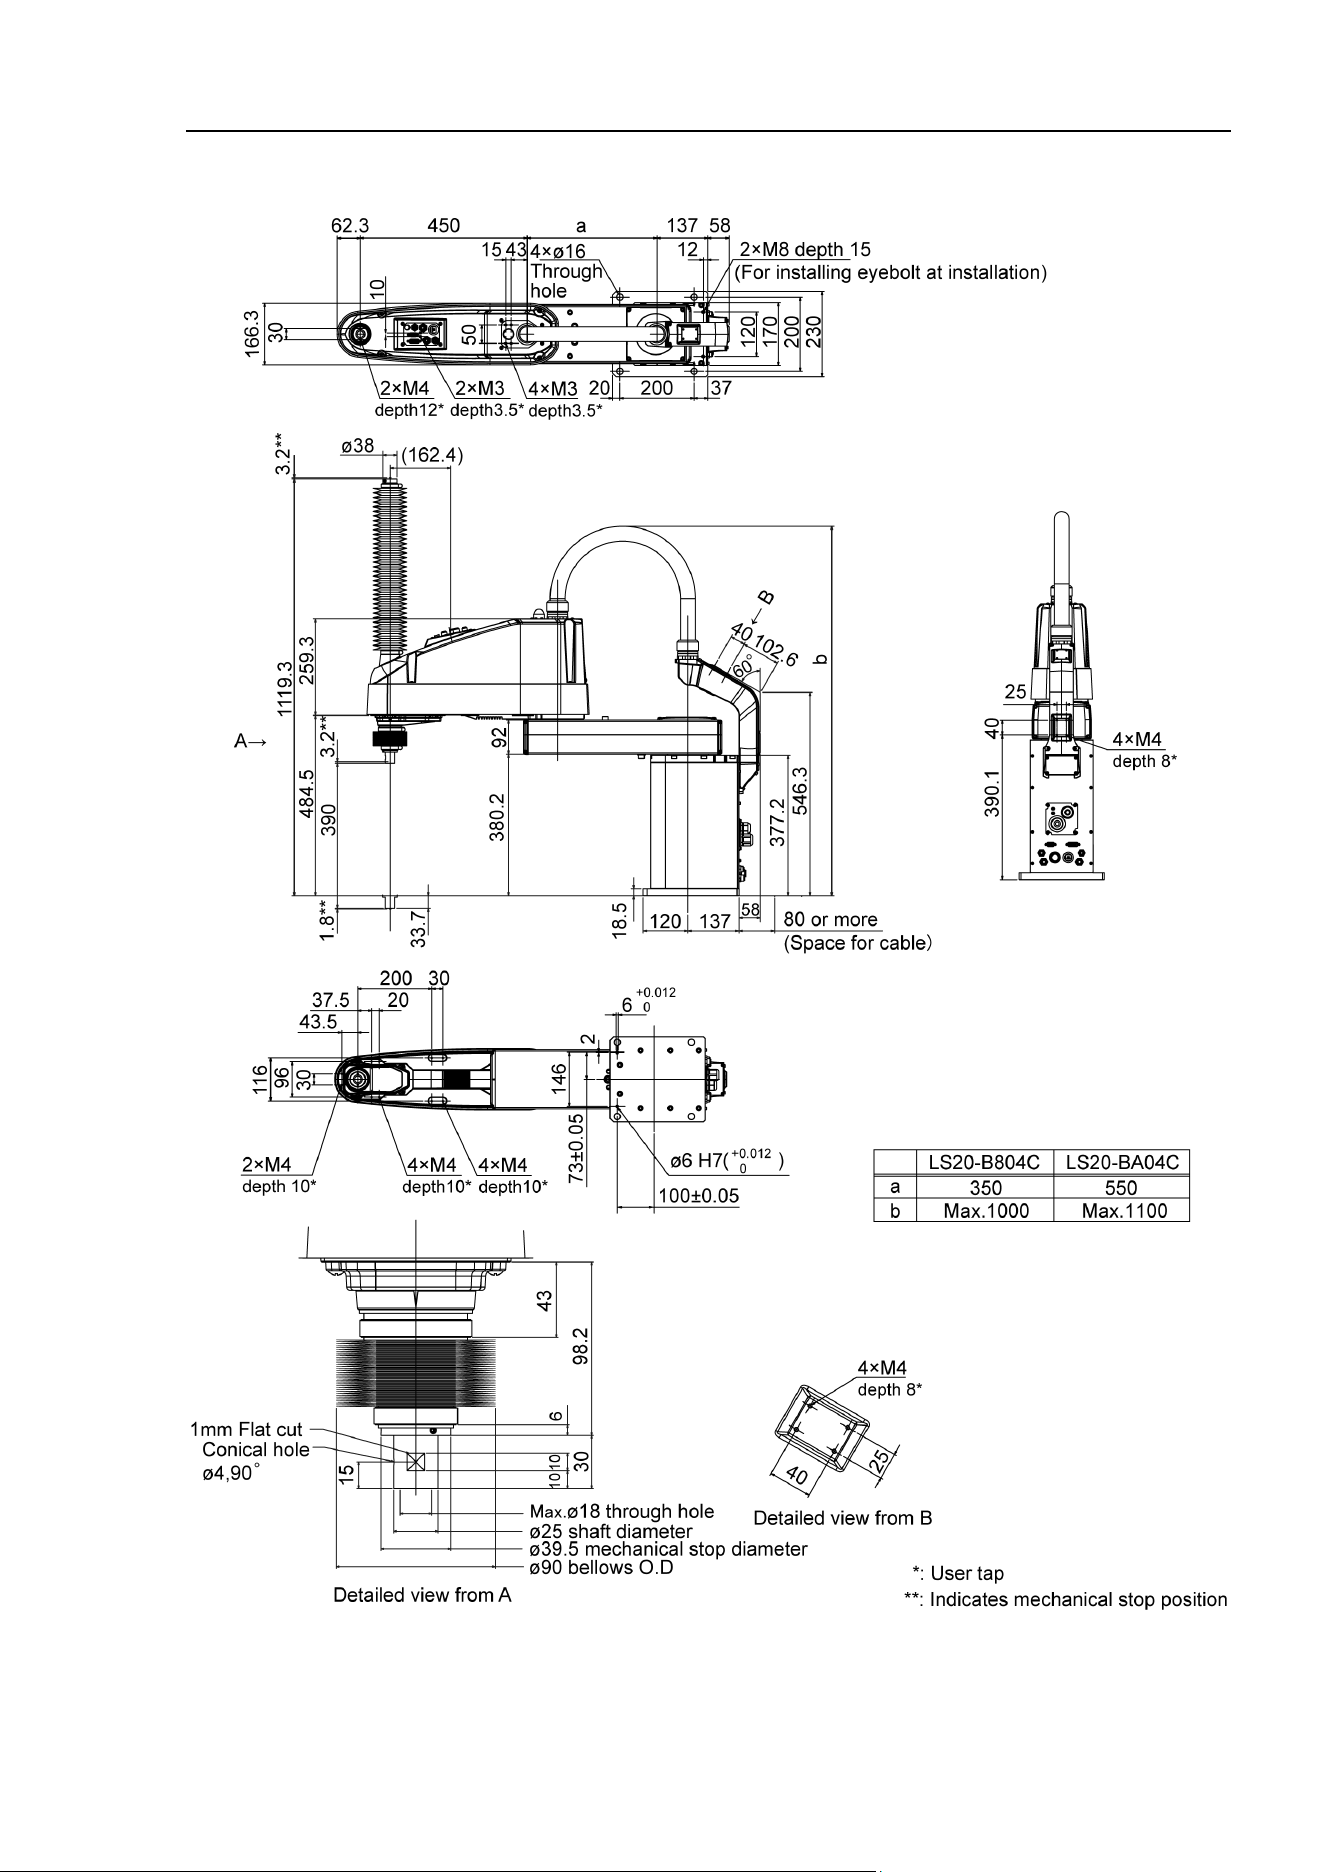
2.3.2 Cleanroom-Model (LS20-B**4C)
The following figures show the additional parts and specifications for Cleanroom-model
when compared with the Standard-model in appearance.
Upper bellows
Lower bellows
Exhaust port
Setup & Operation 2. Specifications
LS20-B Rev.4 19
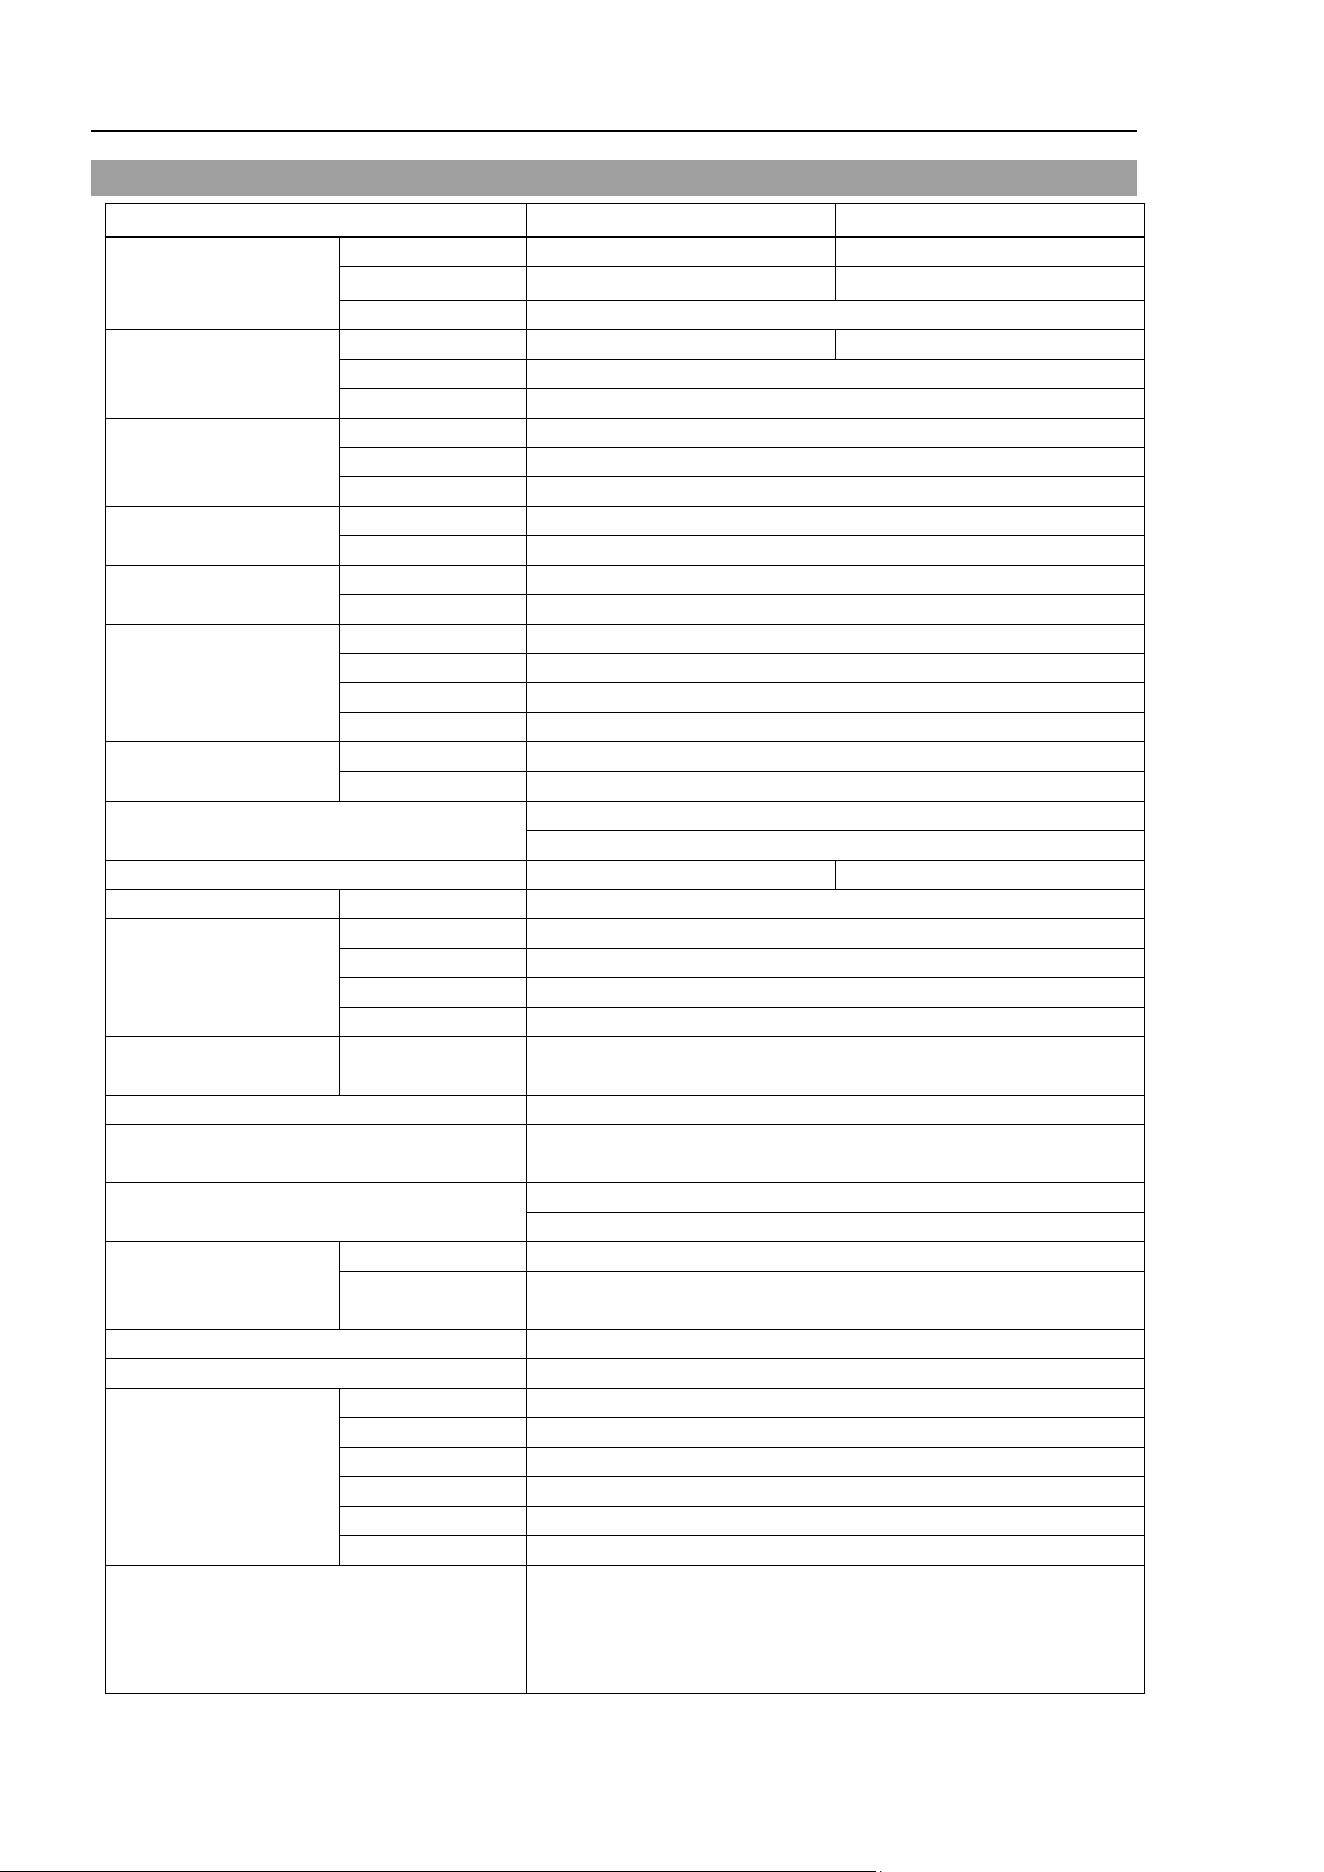
Cleanroom-Model (LS20-B**4C)
Setup & Operation 2. Specifications
20
LS20-B Rev.4
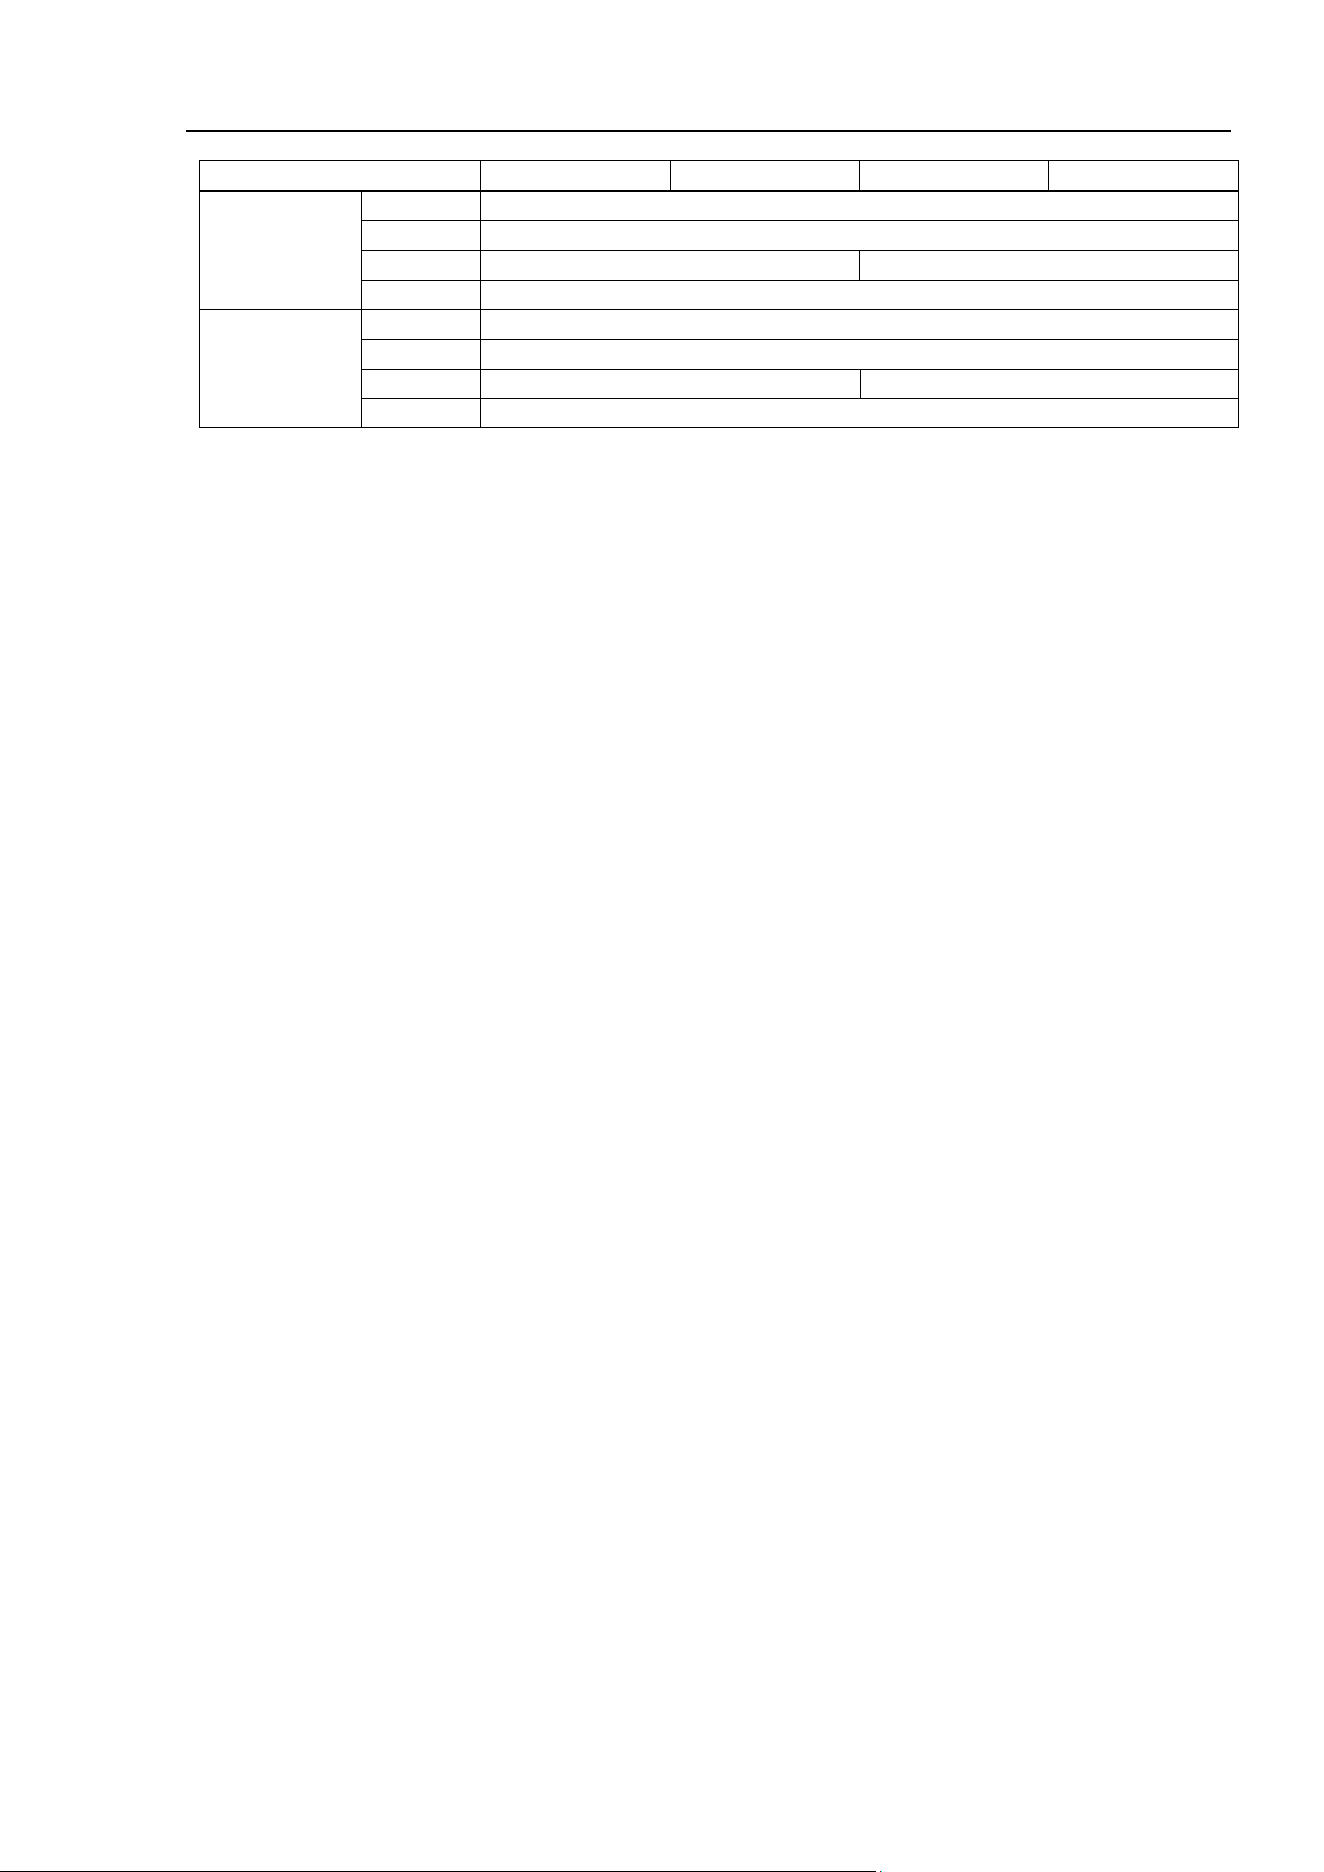
2.4 Specifications
Item
LS20-B804*
LS20-BA04*
Arm length
Arms #1+#2
800 mm
1000 mm
Arm #1
350 mm
550 mm
Arm #2
450 mm
Max. operating speed
*1
Joints #1+#2
9940 mm/s
11250 mm/s
Joint #3
2300 mm/s
Joint #4
1400°/s
Repeatability
Joints #1+#2
± 0.025 mm
Joint #3
± 0.01 mm
Joint #4
± 0.01°
Payload (Load)
Rated
10 kg
Max.
20 kg
Joint #4 allowable
moment of inertia *2
Rated
0.05 kg·m
2
Max.
1.00 kg·m
2
Resolution
Joint #1
0.000275°/pulse
Joint #2
0.000439
°
/pulse
Joint #3
0.00148 mm/pulse
Joint #4
0.001046°/pulse
Hand
Shaft diameter
ø 25 mm
Through hole
ø 18 mm
Mounting hole
200 × 200 mm
4 × ø16
Weight (cables not included)
48 kg: 105.8 lbs.
51 kg: 112.5 lbs.
Driving method
All joints
AC servo motor
Motor
rated capacity
Joint #1
750 W
Joint #2
520 W
Joint #3
520 W
Joint #4
150 W
Option
Installation
environment
Cleanroom *3
Joint #3 down force
250 N
Installed wire for customer use
15 pin: D-sub, 9 pin: D-sub
Equivalent to 8 pin (RJ45) Cat.5e
Installed pneumatic tube for customer use
2 pneumatic tubes (ø8 mm): 0.59 MPa (6 kgf/cm
2
: 86 psi)
2 pneumatic tubes (ø6 mm): 0.59 MPa (6 kgf/cm
2
: 86 psi)
Environmental
requirements
Ambient Temp.
5 to 40 °C (with minimum temperature variation)
Ambient relative
humidity
10 ~ 80 % (no condensation)
Noise level *4
L
Aeq
= 70 dB (A) or under
Applicable Controller
RC90-B
Assignable Value
( ) Default values
Speed
1 ~ (3) ~ 100
Accel *5
1 ~ (10) ~ 120
SpeedS
1 ~ (50) ~ 2000
AccelS
1 ~ (200) ~ 10000
Fine
0 ~ (1250) ~ 65535
Weight
0,450 ~ (10,450) ~ 20,450
Safety standard
CE Marking
EMC Directive, Machinery Directive, RoHS Directive
KC Marking, KCs Marking
ANSI/RIA R15.06
NFPA 79
Setup & Operation 2. Specifications
LS20-B Rev.4 21
Item
LS20-B804S
LS20-BA04S
LS20-B804C
LS20-BA04C
Max.
motion range
Joint #1
± 132
°
Joint #2
± 152
°
Joint #3
420 mm
390 mm
Joint #4
± 360
°
Max.
pulse range
Joint #1
− 152918 ~ 808278
Joint #2
± 345885
Joint #3
−283853 ~ 0
−263578~0
Joint #4
± 344064
*1: In the case of PTP command.
Maximum operating speed for CP command is 2000 mm/s on horizontal plane.
*2: In the case where the center of gravity is at the center of Joint #4.
If the center of gravity is not at the center of Joint #4, set the parameter using Inertia setting.
*3: The exhaust system in the Cleanroom-model Manipulator draws air from the base interior and arm cover
interior together. A crack or other opening in the base unit can cause loss of negative air pressure in the
outer part of the arm, which can cause increased dust emission.
Cleanliness level : Class ISO 4 (ISO14644-1)
Exhaust System : Exhaust port diameter : Inner diameter: ø12 mm
Exhaust tube : Polyurethane tube
Outer diameter: ø12 mm (Inner diameter: ø8 mm)
Recommended exhaust flow rate : approx. 1000 cm
3
/s (Normal)
*4: Conditions of Manipulator during measurement as follows:
Operating conditions : Under rated load, 4-joints simultaneous motion, maximum speed, maximum
acceleration/deceleration, and duty 50%.
Measurement point : Rear of the Manipulator, 1000 mm apart from the motion range, 50 mm above the
base-installed surface.
*5: In general use, Accel setting 100 is the optimum setting that maintains the balance of acceleration and
vibration when positioning. Although values larger than 100 can be set to Accel, it is recommended to
minimize the use of large values to necessary motions since operating the manipulator continuously with
the large Accel setting may shorten the product life remarkably.
Setup & Operation 2. Specifications
22
LS20-B Rev.4
2.5 How to Set the Model
The Manipulator model for your system has been set before shipment from the factory.
It is normally not required to change the model when you receive your system.
CAUTION
■
When you need to change the setting of the Manipulator model, be sure to set the
Manipulator model properly.
Improper setting of the Manipulator model may
result in
abnormal or no operation of the Manipulator and/or cause safety
problems.
If the custom specifications number (MT***) is described on MODEL of the signature label
(S/N label), the Manipulator has custom specifications. (A label with only the custom
specifications number may be attached depending on shipment time.)
The custom specifications may require a different configuration procedure; check the
custom specifications number (MT***) and contact the supplier of your region when
necessary.
The Manipulator model can be set from software.
Refer to the chapter Robot Configuration in EPSON RC+ User’s Guide.
NOTE
Setup & Operation 3. Environments and Installation
LS20-B Rev.4 23
3. Environments and Installation
3.1 Environmental Conditions
A suitable environment is necessary for the robot system to function properly and safely.
Be sure to install the robot system in an environment that meets the following conditions:
Item
Conditions
Ambient temperature
*
5 to 40°C (with minimum temperature variation)
Ambient relative humidity
10 to 80% (no condensation)
First transient burst noise
1 kV or less (Signal wire)
Electrostatic noise
4 kV or less
Environment · Install indoors.
· Keep away from direct sunlight.
· Keep away from dust, oily smoke, salinity, metal
powder or other contaminants.
· Keep away from flammable or corrosive solvents
and gases.
· Keep away from water.
· Keep away from shocks or vibrations.
· Keep away from sources of electric noise.
Manipulators are not suitable for operation in harsh environments such as painting areas, etc.
When using Manipulators in inadequate environments that do not meet the above conditions,
please contact the supplier of your region.
* The ambient temperature conditions are for the Manipulators only. For the Controller
the Manipulators are connected to, refer to the Controller manual.
Special Environmental Conditions
The surface of the Manipulator has general oil resistance. However, if your
requirements specify that the Manipulator must withstand certain kinds of oil, please
contact the supplier of your region.
Rapid change in temperature and humidity can cause condensation inside the Manipulator.
If your requirements specify that the Manipulator handles food, please contact the supplier
of your region to check whether the Manipulator will damage the food or not.
The Manipulator cannot be used in corrosive environments where acid or alkaline is used.
In a salty environment where the rust is likely to gather, the Manipulator is susceptible to
rust.
WARNING
■
Use an earth leakage breaker on the AC power cable of the
Controller to avoid
electric shock and circuit breakdown caused by
short circuit.
P
repare the earth leakage breaker that pertains the Controller you are using.
For details, refer to the
Controller manual.
CAUTION
■
When cleaning the Manipulator, do not rub it strongly with alcohol or
benzene.
It may lose luster on the coated face.
NOTE
Setup & Operation 3. Environments and Installation
24
LS20-B Rev.4
3.2 Base Table
A base table for anchoring the Manipulator is not supplied. Please make or obtain the base
table for your Manipulator. The shape and size of the base table differs depending on the
use of the robot system. For your reference, we list some Manipulator table requirements
here.
The base table must not only be able to bear the weight of the Manipulator but also be able
to withstand the dynamic movement of the Manipulator when it operates at maximum
acceleration/deceleration. Ensure that there is enough strength on the base table by
attaching reinforcing materials such as crossbeams.
The torque and reaction force produced by the movement of the Manipulator are as follows:
LS20-B
Max. reaction torque on the horizontal plate
1000
N·m
Max. horizontal reaction force
7500
N
Max. vertical reaction force
2000
N
The threaded holes required for mounting the Manipulator base are M12. Use mounting
bolts with specifications conforming to ISO898-1 property class: 10.9 or 12.9.
For dimensions, refer to Setup & Operation: 3.3 Mounting Dimensions.
The plate for the Manipulator mounting face should be 20 mm thick or more and made of
steel to reduce vibration. The surface roughness of the steel plate should be 25 μm or less.
The table must be secured on the floor or wall to prevent it from moving.
The Manipulator must be installed horizontally.
When using a leveler to adjust the height of the base table, use a screw with M16 diameter
or more.
If you are passing cables through the holes on the base table, see the figures below.
Power Cable
Connector
Signal Cable
Connector
44
18
63
15
M/C Cables
(Unit : mm)
40
80
D
o not remove the M/C cables from the Manipulator.
For environmental conditions regarding space when placing the Controller on the base table,
refer to the Controller manual.
WARNING
■
To ensure safety, a safeguard must be installed
for the robot system.
For details on the
safeguard, refer to the EPSON RC+ User’s Guide.
NOTE
Setup & Operation 3. Environments and Installation
LS20-B Rev.4 25
3.3 Mounting Dimensions
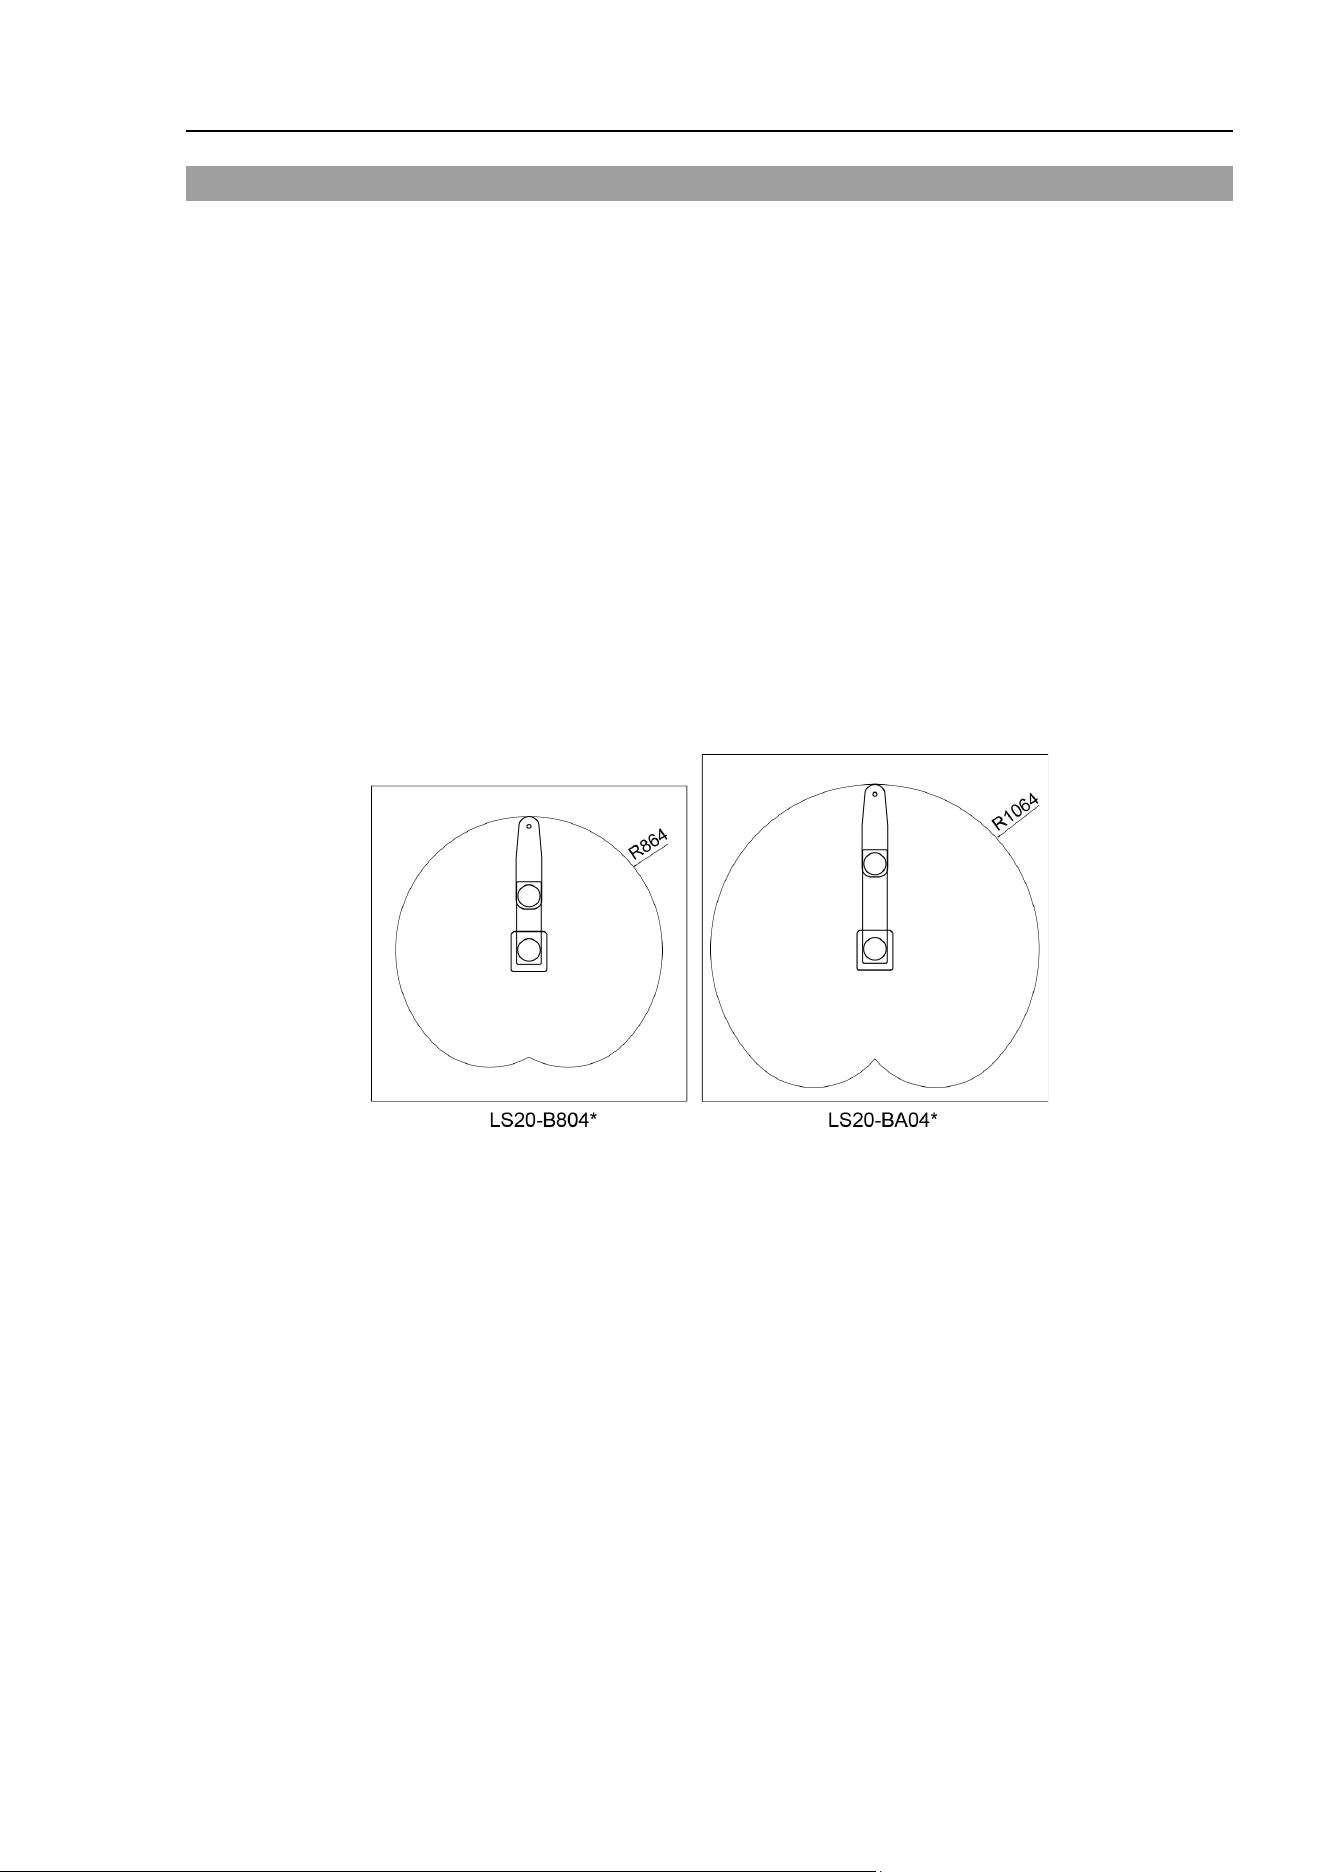
The maximum space (R) includes the radius of the end effector. If it exceeds 60 mm, define
the radius as the distance to the outer edge of maximum space.
If a camera or solenoid valve extends outside of the arm, set the maximum range including
the space that they may reach.
Be sure to allow for the following extra spaces in addition to the space required for mounting
the Manipulator, Controller, and peripheral equipment.
Space for teaching
Space for maintenance and inspection
(Ensure a space to open the covers and plates for maintenance.)
Space for cables
The minimum bend radius of the power cable is 90 mm. When installing the cable, be sure
to maintain sufficient distance from obstacles. In addition, leave enough space for other
cables so that they are not bent forcibly.
Ensure distance to the safeguard from the maximum motion range is more than 100 mm.
Setup & Operation 3. Environments and Installation
26
LS20-B Rev.4
3.4 Unpacking and Transportation
T
HE INSTALLATION SHALL BE PREFORMED BY QUALIFIED INSTALLATION
PERSONNEL AND SHOULD CONFORM TO ALL NATIONAL AND LOCAL CODES.
WARNING
■
Only authorized personnel
should perform sling work and operate a crane and a
forklift. When
these operations are performed by unauthorized personnel, it is
extremely
hazardous and may result in serious bodily injury and/or severe
equipment damage to the robot system.
■
Stabilize the Manipulator with your hands when hoisting it. Unstable hoisting is
extremely hazardous and may result in serious bodily injury and/or severe
equipment damage to the robot system as the fall of the Manipulator.
CAUTION
■
Using a cart or
similar equipment, transport the Manipulator in the same manner
as it was delivered.
■
After
removing the bolts securing the Manipulator to the delivery equipment, the
Manipulator
can fall. Be careful not to get hands or fingers caught.
■
The arm is
secured with a wire tie. Leave the wire tie secured until you finish the
installation so as not to get hands or fingers caught
.
■
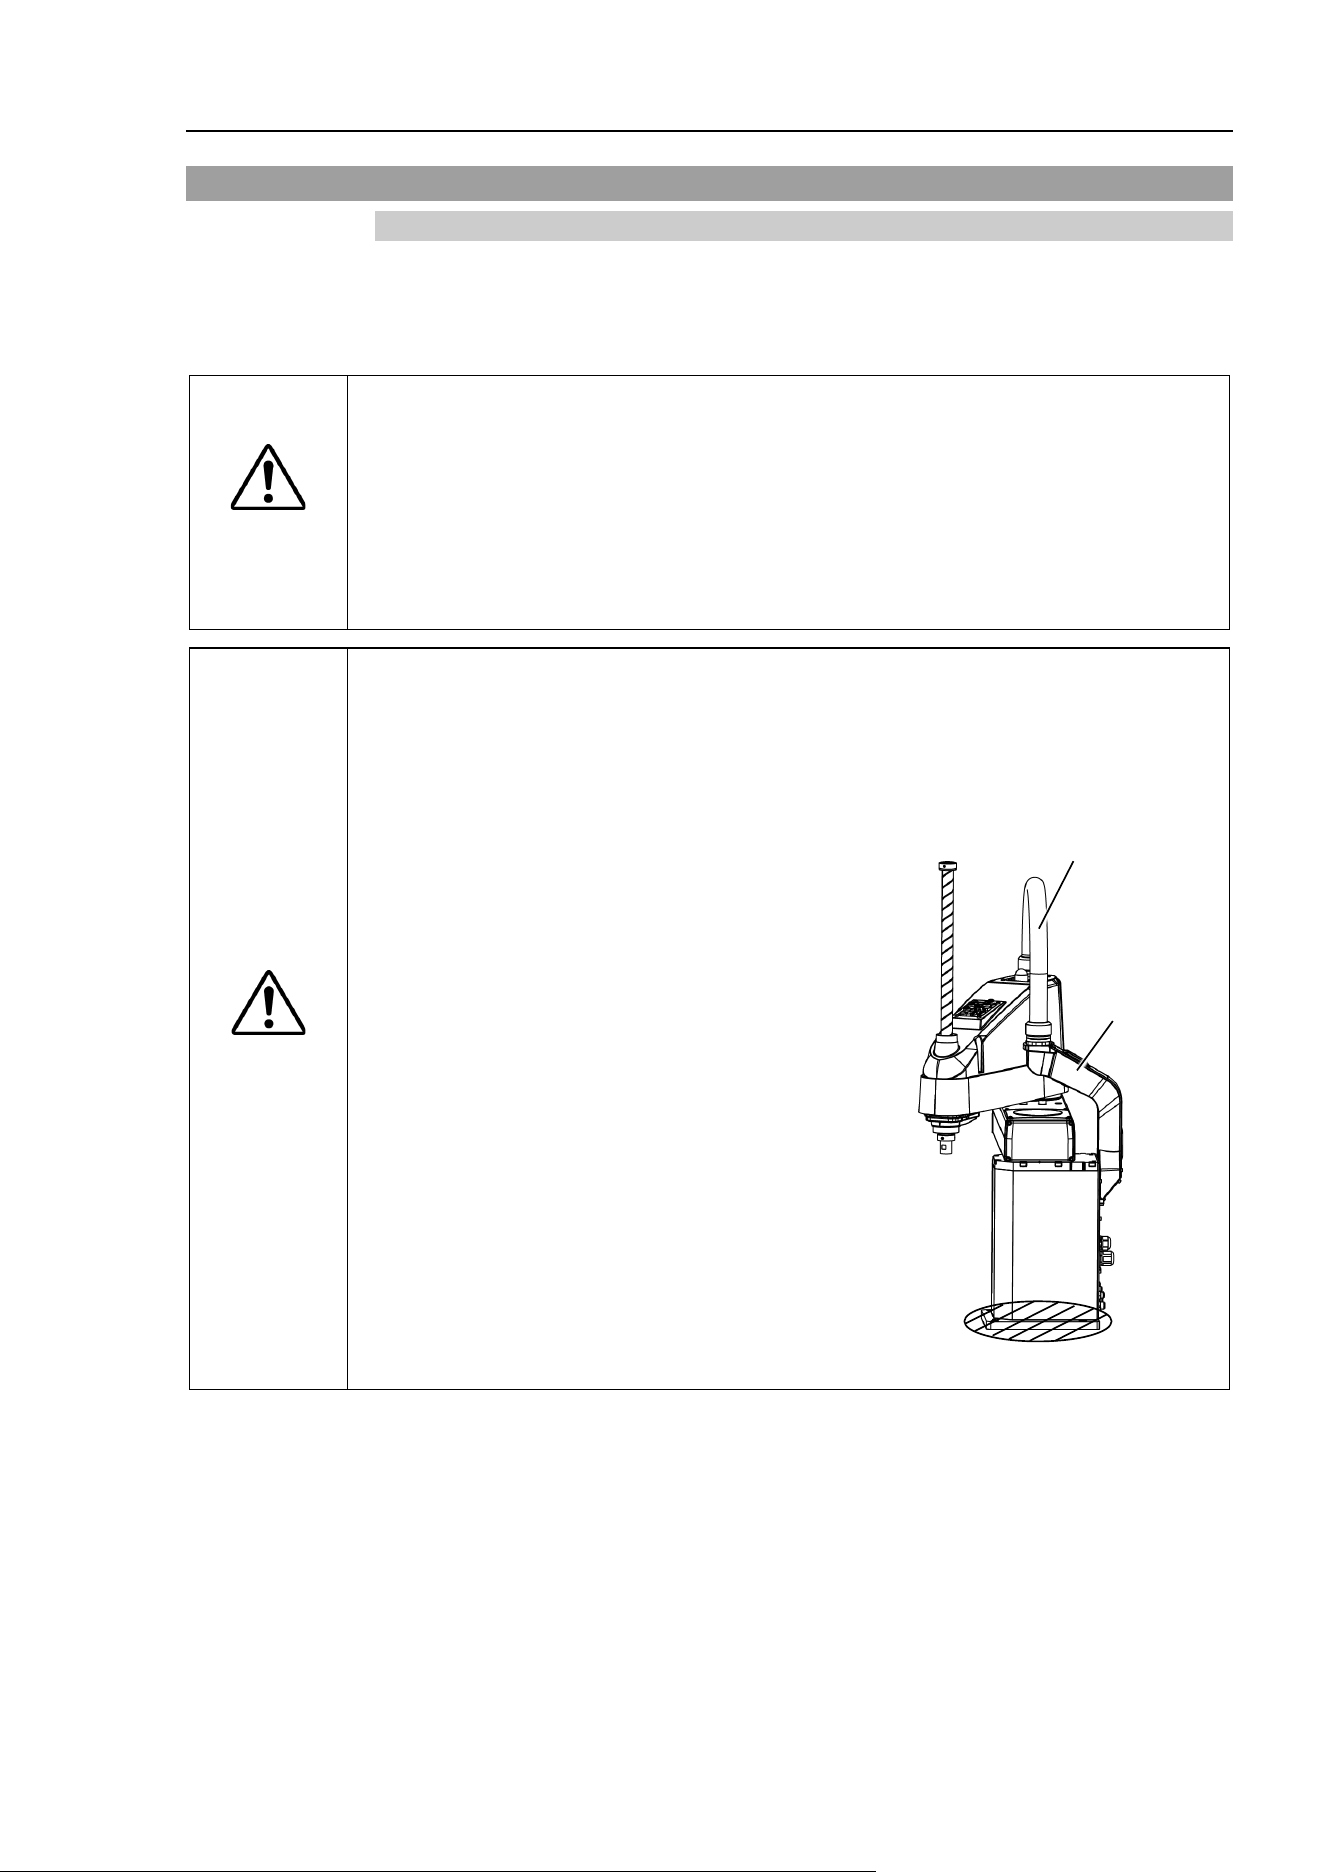
To transport the Manipulator, secure it to the
delivery equipment or have at least
2 people to
hold it by hand.
Also, do not hold the bottom of the base (the
shaded area
in the figure). Holding the area by
hand is extremely hazardous and may cause your
hands and fingers caught.
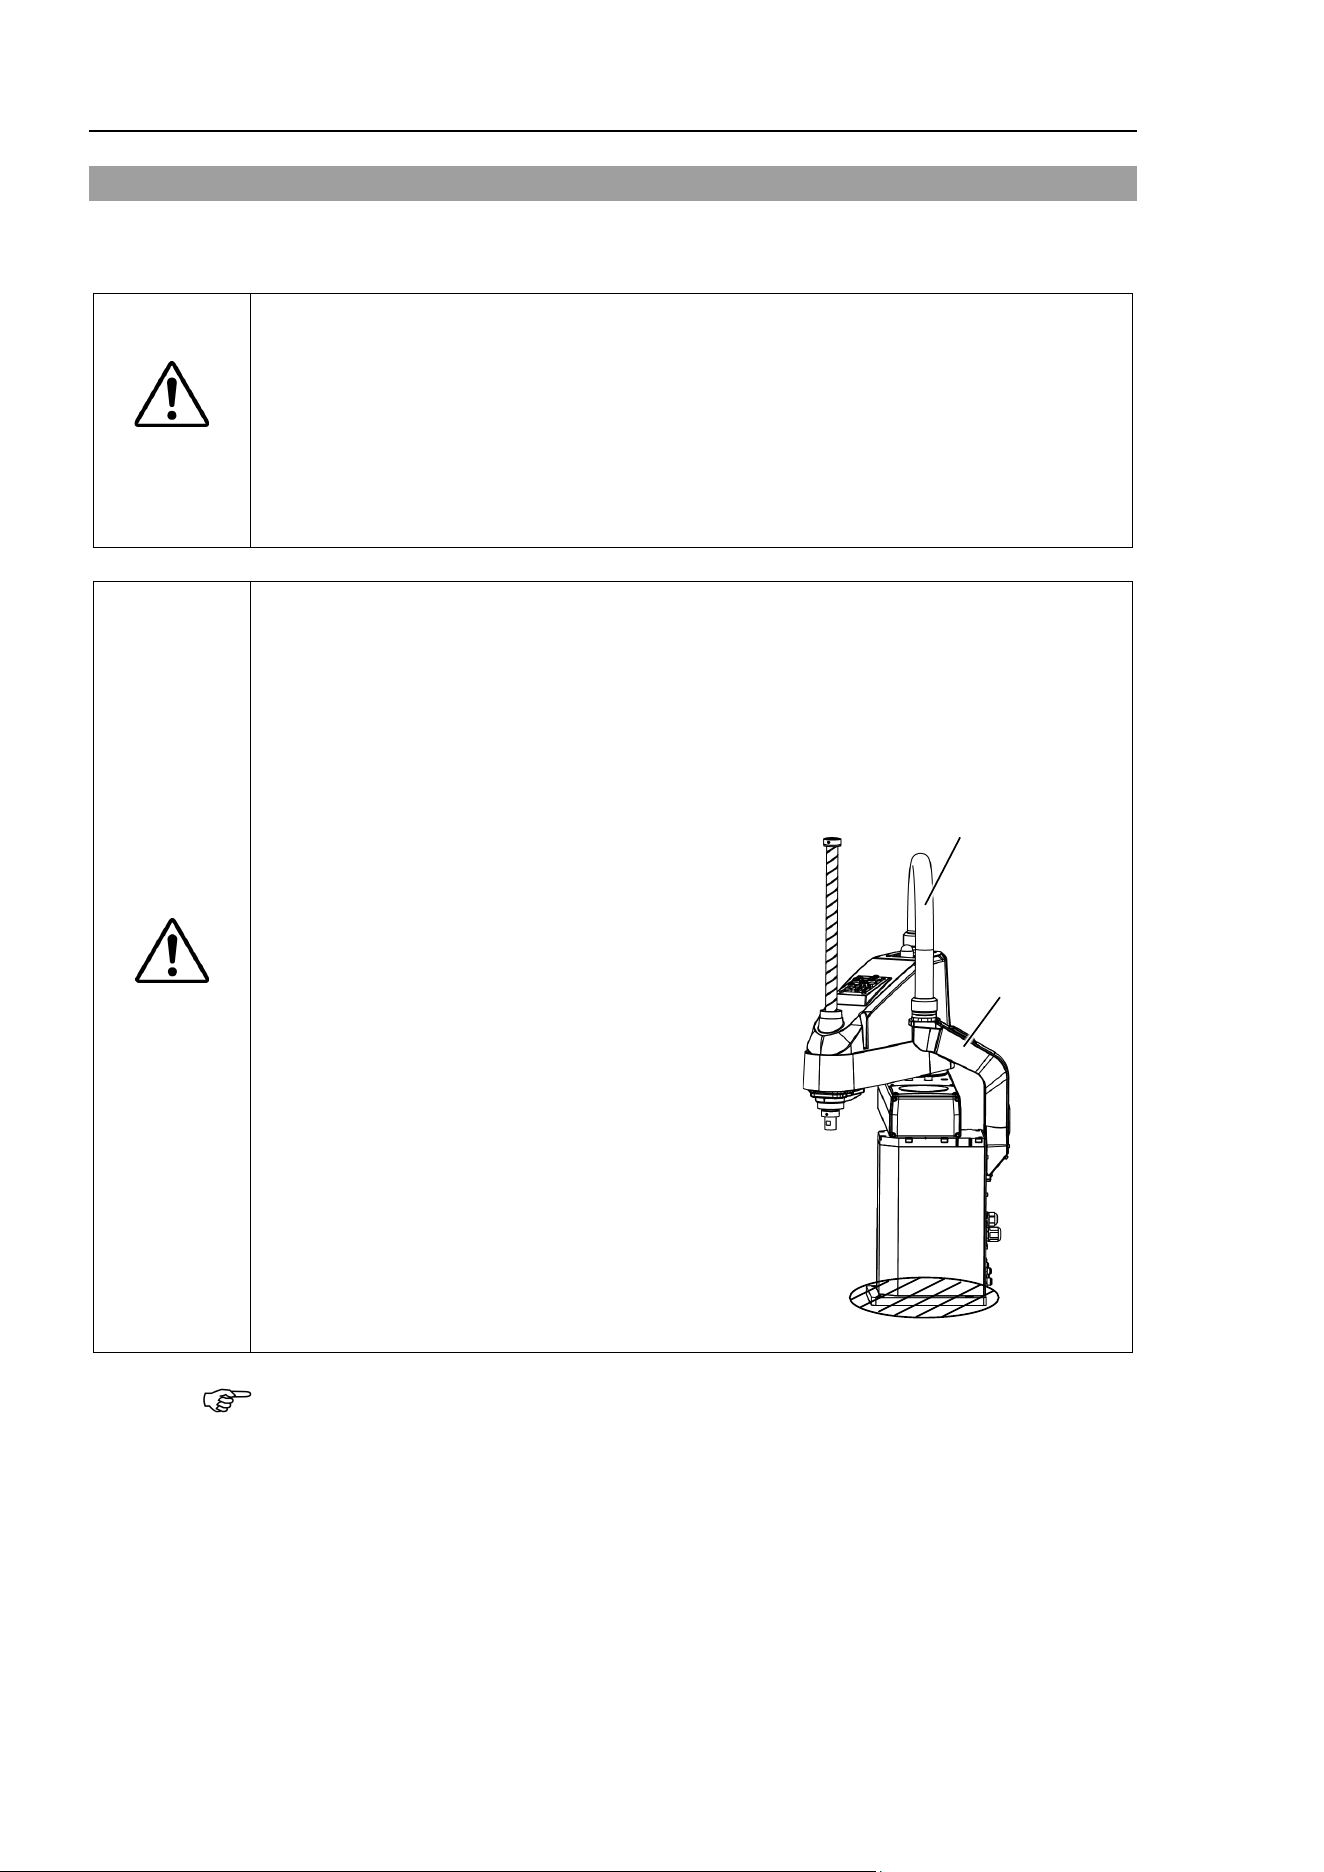
L
S20-B804*: approx. 48 kg: 105.8 lbs.
LS20-BA04*: approx. 51 kg: 112.5 lbs.
Metal Duct
Resin Duct
(Figure: LS20-B804S)
■
Do not hold the metal duct and the resin duct
when
transporting the Manipulator.
Doing so
may damage them.
When transporting the Manipulator for a long distance, secure it to the delivery equipment
directly so that the Manipulator never falls over.
If necessary, pack the Manipulator in the same style as it was delivered.
NOTE
Setup & Operation 3. Environments and Installation
LS20-B Rev.4 27
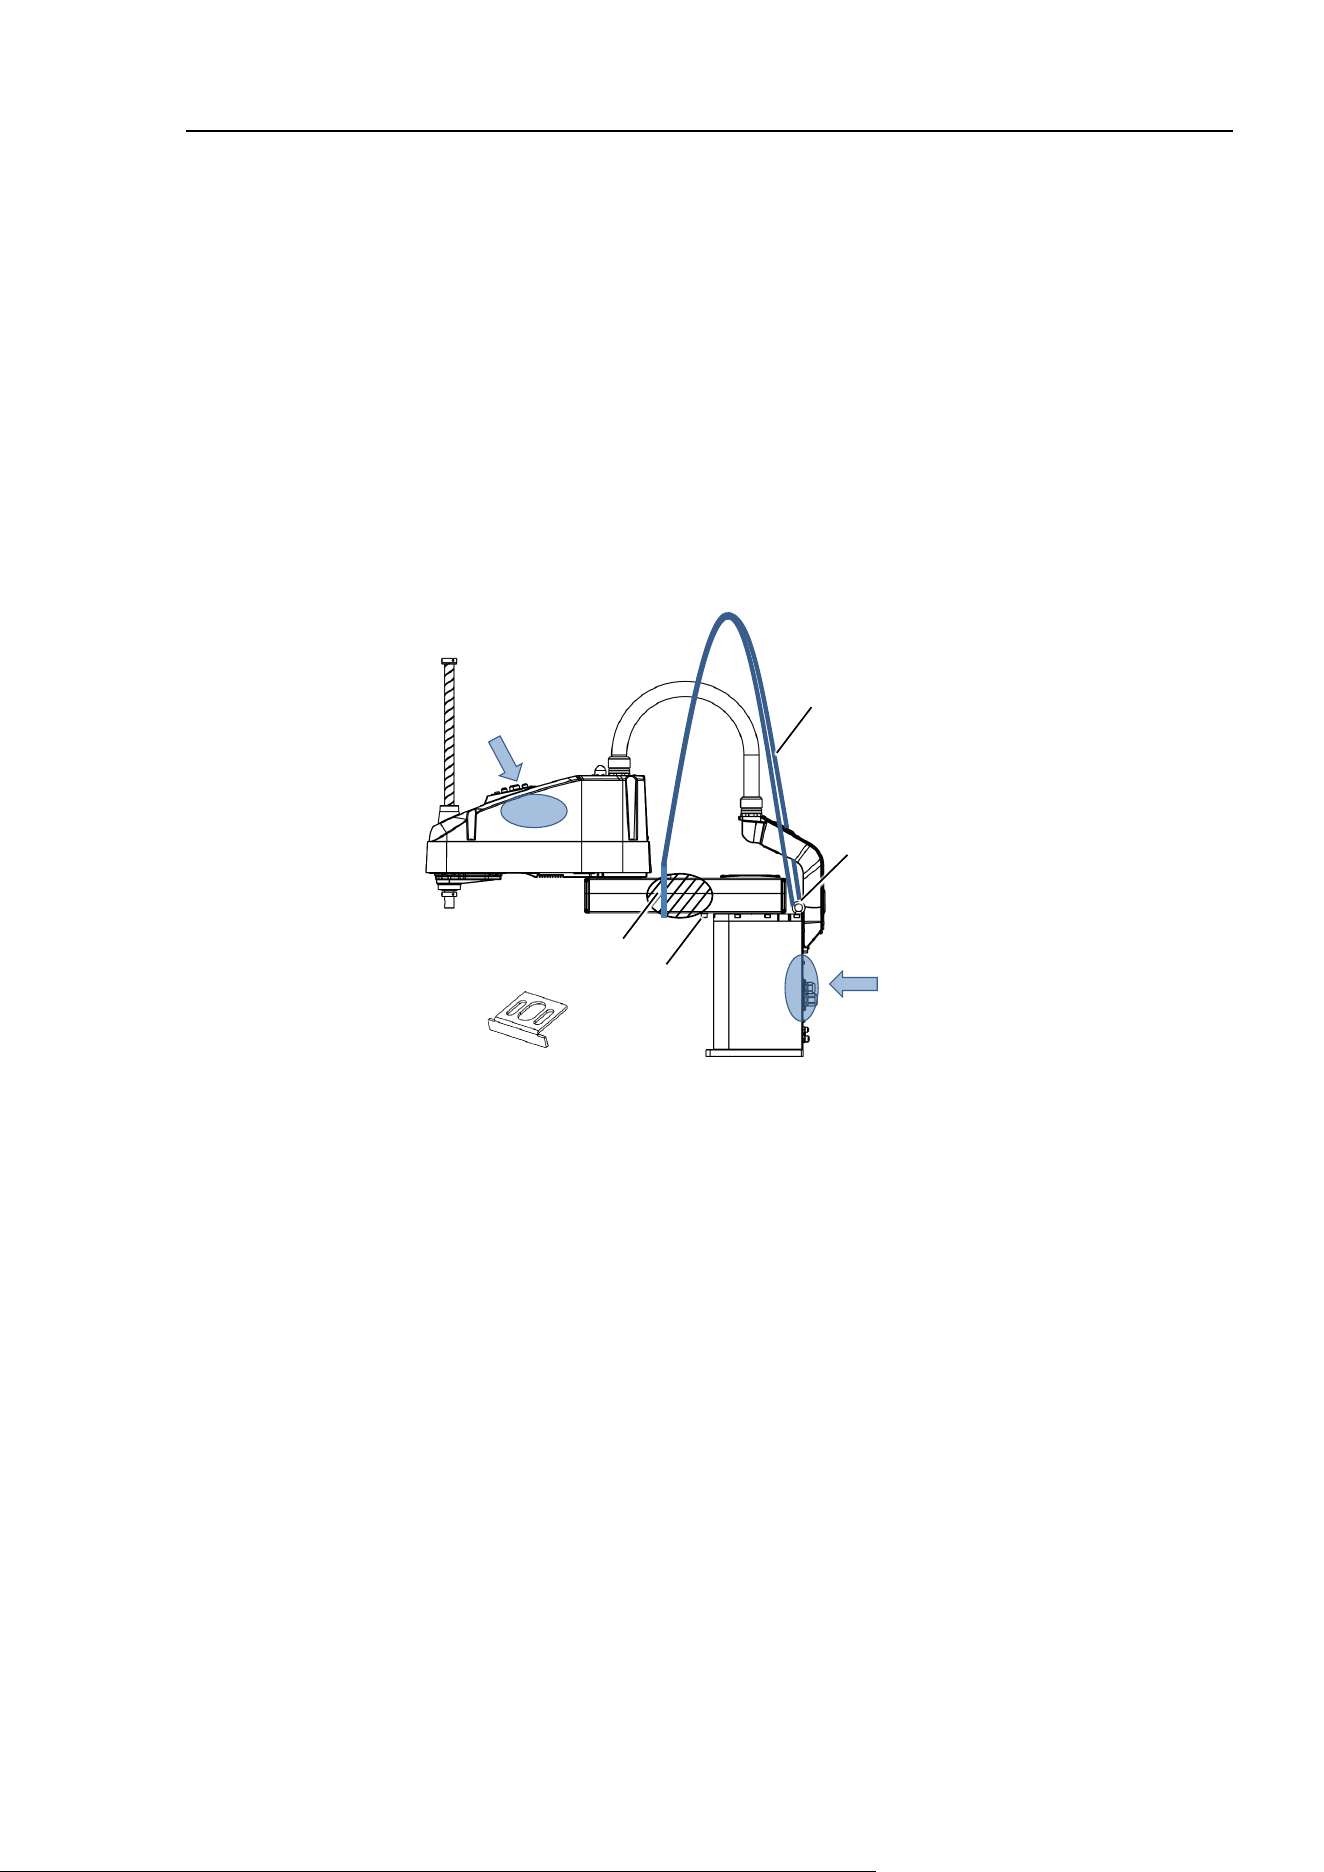
Transport the Manipulator following the instructions below:
(1) Attach the eyebolts to the upper side of the Base.
(2) Turn the Arm #1 to face the front.
(3) Fix the Arm #1 using the arm lock so that it cannot move.
(4) Use the wire tie to fix the belt for hoisting to the Arm #1.
Set the wire tie at the shaded area in the figure below so that the belt cannot move.
(5) Pass the belts through the wire tie and eyebolts.
(6) Hoist the Manipulator slightly so that it does not fall over. Then, remove the bolts
securing the Manipulator to the delivery equipment or a pallet.
(7) Hoist the Manipulator attaching the hands at the positions indicated by arrows so that
it can keep the balance. Then, move the Manipulator to the base table.
Arm Lock (2-M10×65)
z
Eyebolts
Wire tie
Belt
Setup & Operation 3. Environments and Installation
28
LS20-B Rev.4
3.5 Installation Procedure
CAUTION
■
The robot system
must be installed to avoid interference with buildings, structures,
utilities, other
machines and equipment that may create a trapping hazard or pinch
points.
■
Vibration
(resonance) may occur during operation depending on rigidity of the
installation table.
If the
vibration occurs, improve rigidity of the table or change the speed or
acceleration
and deceleration settings.
3.5.1 Standard-Model
C
AUTION
■
Install the
Table Top Mounting Manipulator with two or more people.
The Manipulator weigh
ts are as follows. Be careful not to get hands, fingers, or
feet caught and/or have equipment damage
d by a fall of the Manipulator.
LS20-B8
04*: approx. 48 kg: 105.8 lbs.
LS20-BA
04*: approx. 51 kg: 112.5 lbs.
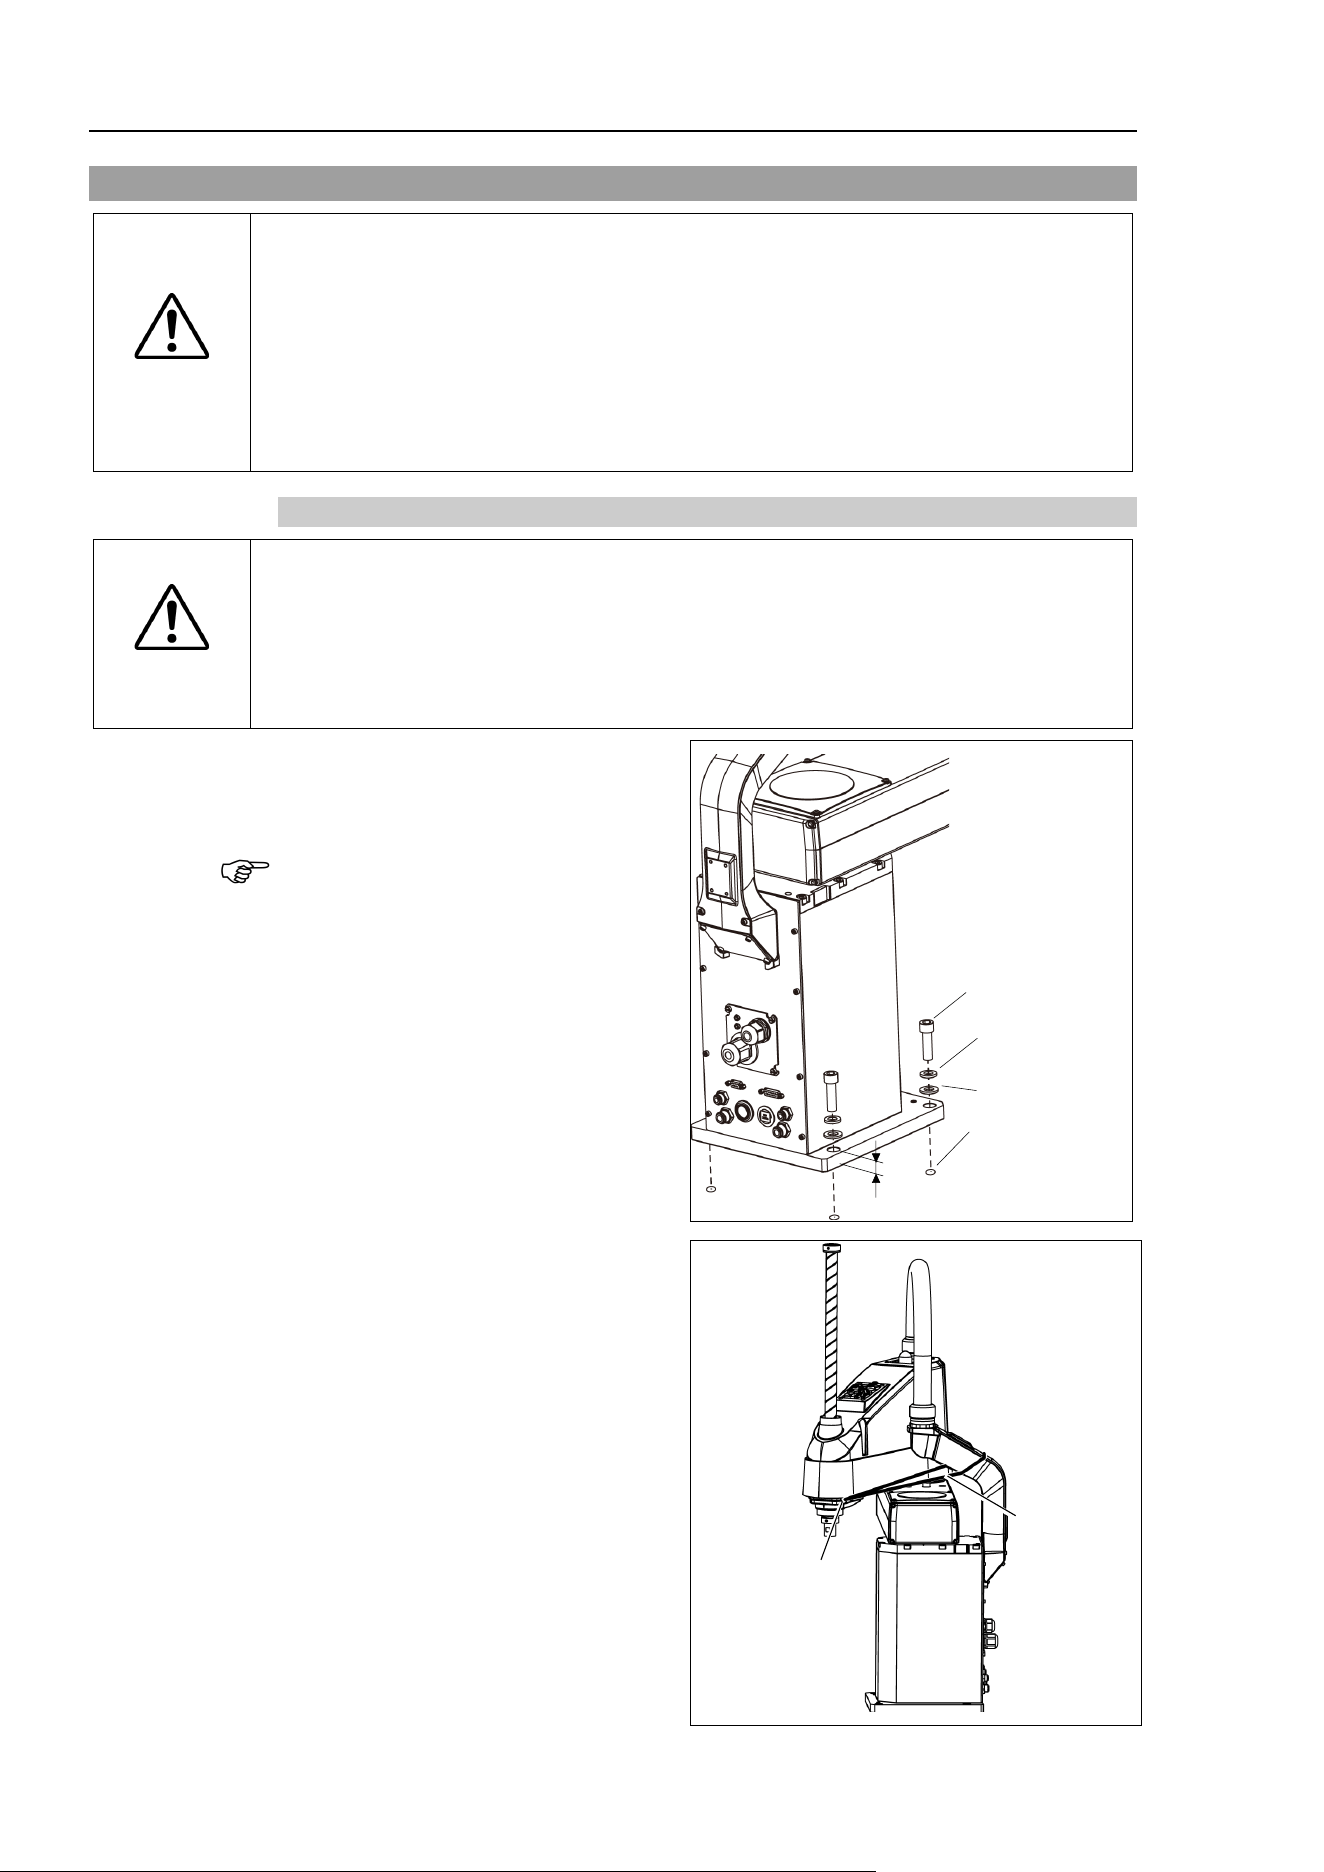
(1)
Secure the base to the base table with
four bo
lts.
Use bolts
with specifications
conforming
to ISO898-1 Property
C
lass: 10.9 or 12.9.
Tightening torque:
73.5 N·m (750 kgf·cm)
18.5 mm
Screw Hole
(Depth
20 mm or more)
4-M12×40
Spring
Washer
Plain Washer
(2)
Using nippers, cut off the wire tie
binding
the arm. Remove the bolt.
Wire tie
Bolt: M4
NOTE
Setup & Operation 3. Environments and Installation
LS20-B Rev.4 29
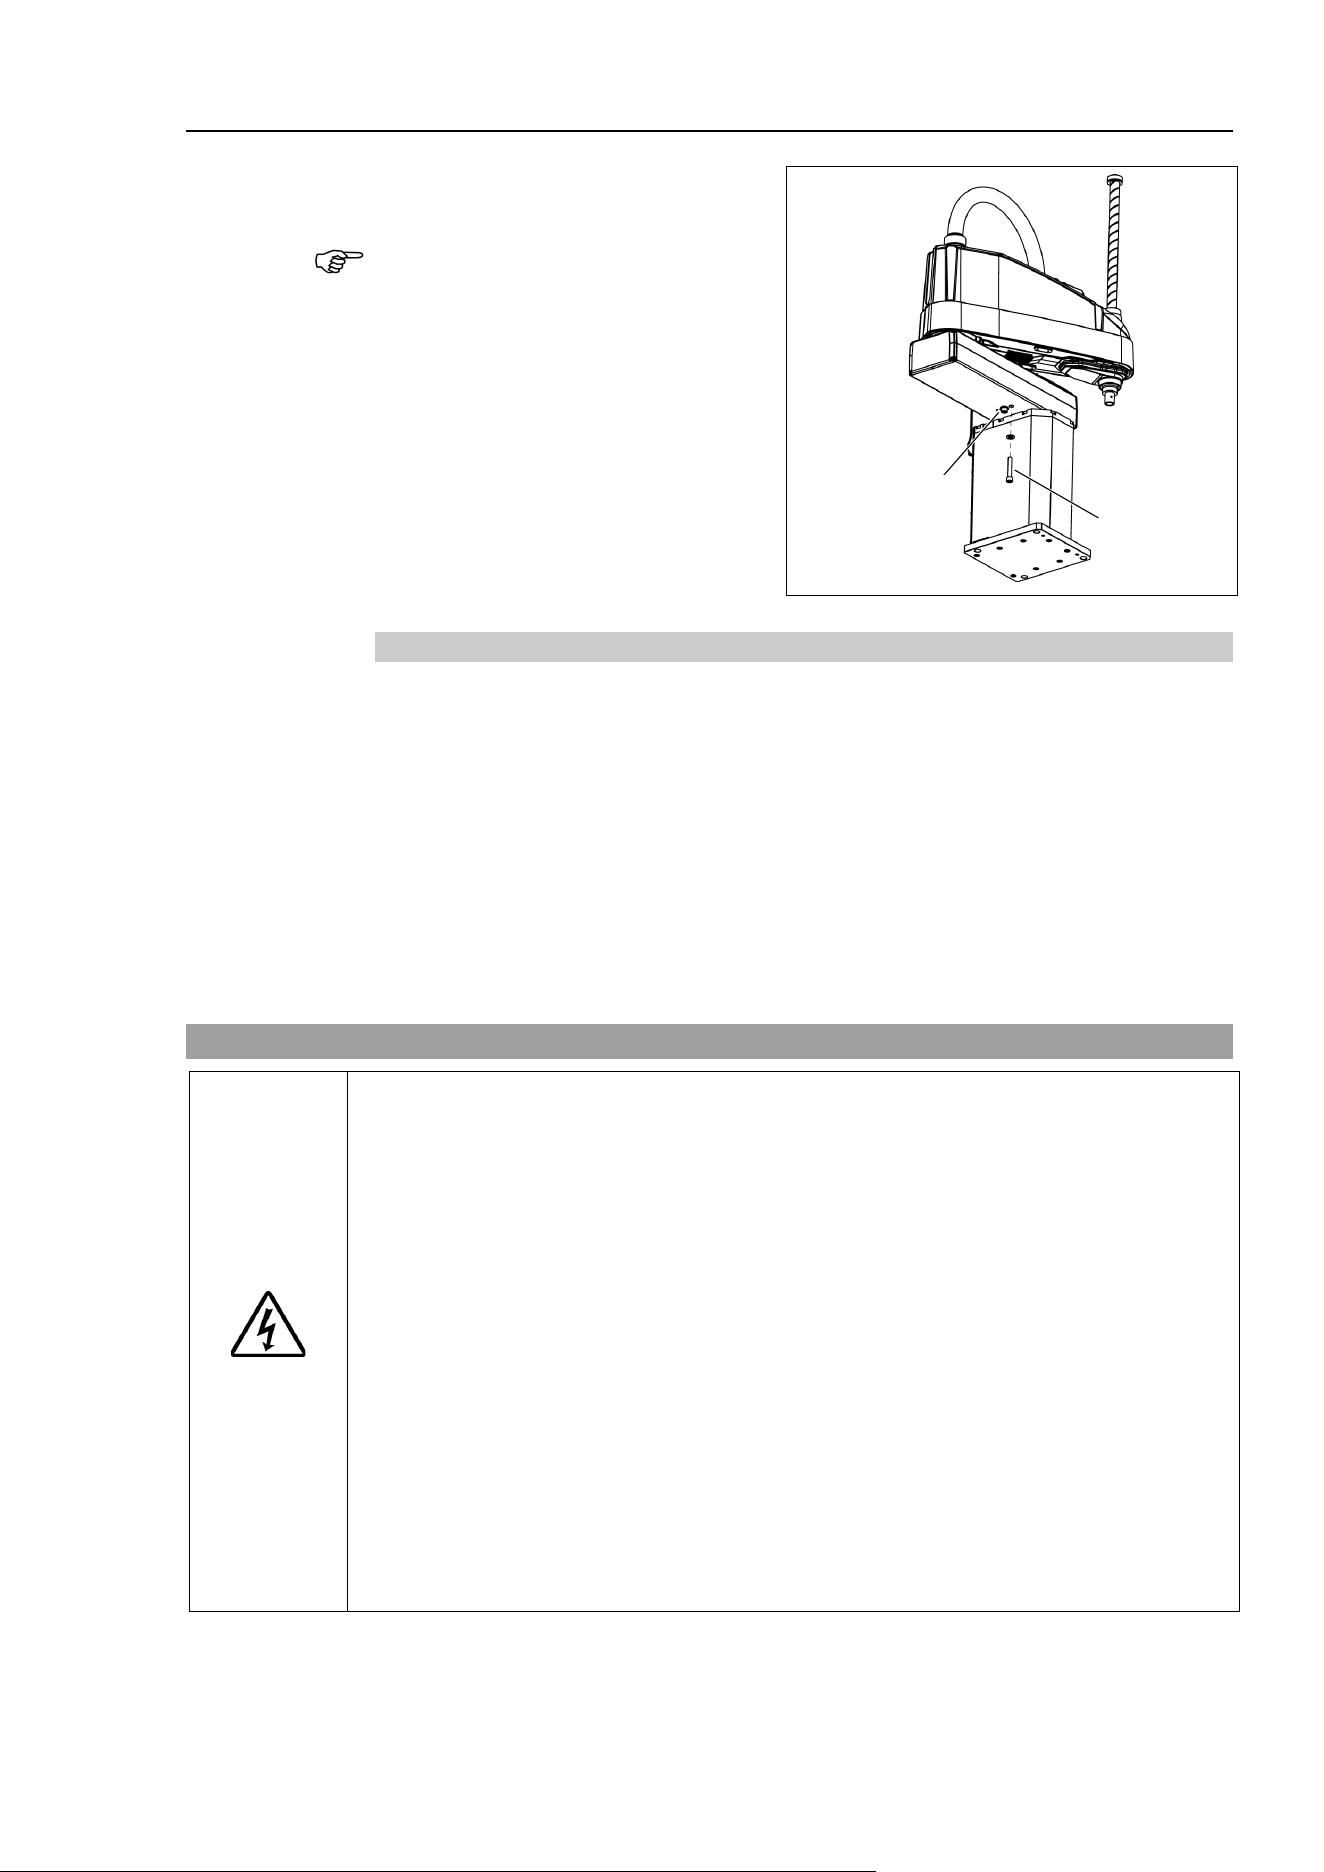
(3)
Remove the screw for fixing the arm.
The removed screw will be
necessary
when
transporting the Manipulator.
Keep it with
the
arm lock which is
supplied
at shipment.
Be careful not to lose
the screw.
Do not remove the mechanical stop.
M10×65
Mechanical Stop
3.5.2 Cleanroom-Model
(1) Unpack the Manipulator outside of the clean room.
(2) Secure the Manipulator to delivery equipment such as a pallet with bolts so that the
Manipulator does not fall over.
(3) Wipe off the dust on the Manipulator with a little alcohol or distilled water on a lint-
free cloth.
(4) Transport the Manipulator to the cleanroom.
(5) Refer to the installation procedure of each Manipulator model and install the
Manipulator.
(6) Connect an exhaust tube to the exhaust port.
3.6 Connecting the Cables
WARNING
■
To shut off power to the robot system, disconnect the power plug from the power
source. Be sure to connect the AC power cable to a power receptacle.
DO NOT connect it directly to a factory power source.
■
Before
performing any replacement procedure, turn OFF the Controller and related
equipment,
and then disconnect the power plug from the power source.
Performing any replacement procedure with the power ON is extremely hazardous
and may result in
electric shock and/or malfunction of the robot system.
■
Be sure to connect the cables properly.
Do not allow unnecessary strain on the
cables. (Do not
put heavy objects on the cables. Do not bend or pull the cables
forcibl
y.) The unnecessary strain on the cables may result in damage to the
cables, disconne
ction, and/or contact failure.
Damaged cables, disconnection, or contact failure is extremely hazardous and may
result in electric shock and/or improper function of the r
obot system.
■
Grounding the manipulator is done by connecting with the controller. Ensure that
the controller is grounded and the cables are correctly connected. If the ground
wire is improperly connected to ground, it may result in the fire or elect
ric shock.
NOTE
Setup & Operation 3. Environments and Installation
30
LS20-B Rev.4
CAUTION
■
When connecting the Manipulator to the Controller, make sure that the serial
numbers on each equipment match. Improper connection between the Manipulator
and Controller may not only cause improper function of the robot system but also
serious safety problems. The connection method varies with the Controller used.
For details on the connection, refer to the Controller manual.
When the Manipulator is a Cleanroom-model, be aware of the followings.
For the Manipulator of Cleanroom-model, use it with an exhaust system.
For details, refer to Setup & Operation: 2.4 Specifications.
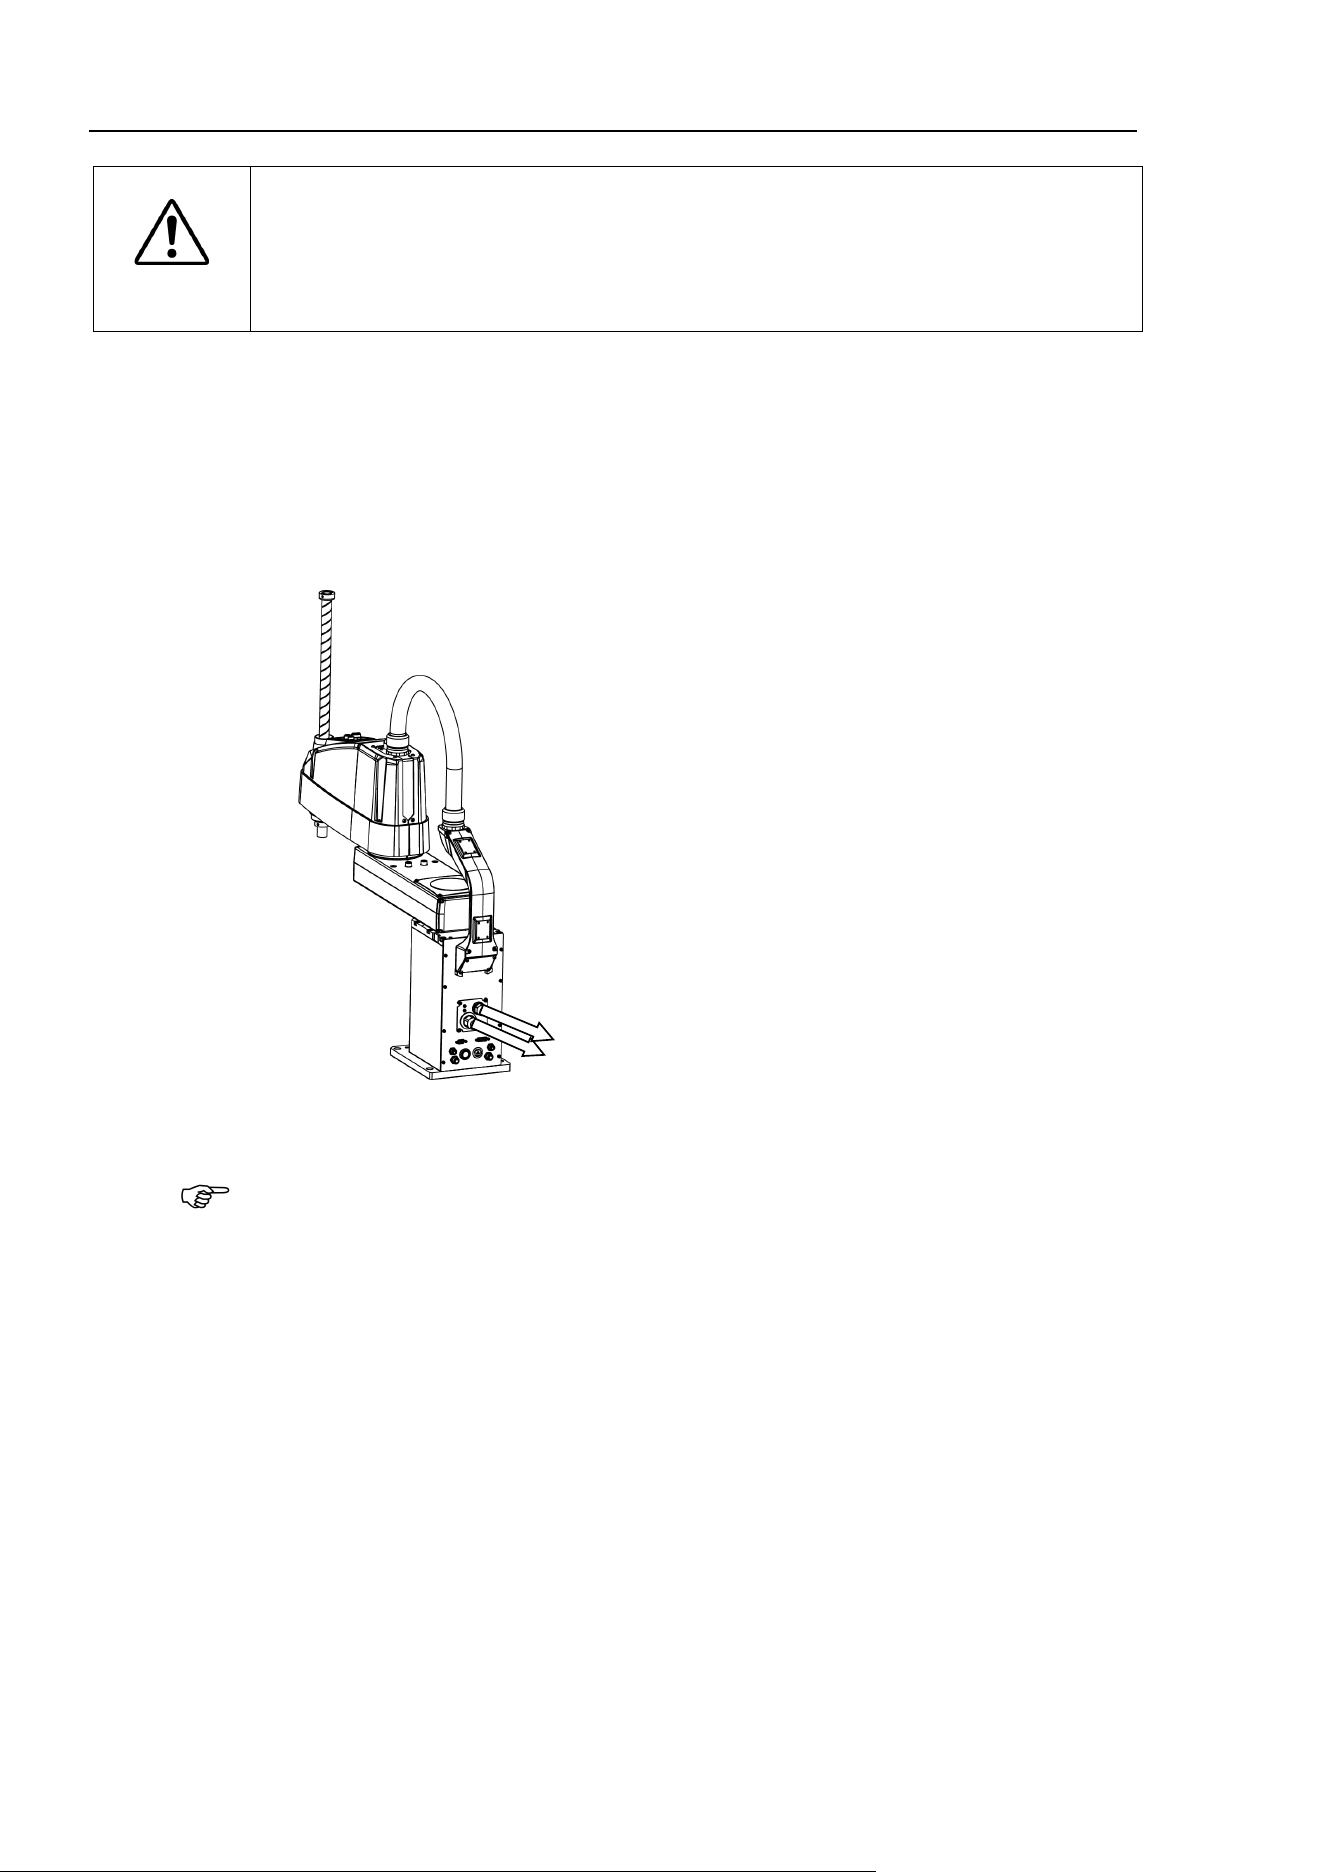
Cable Connections
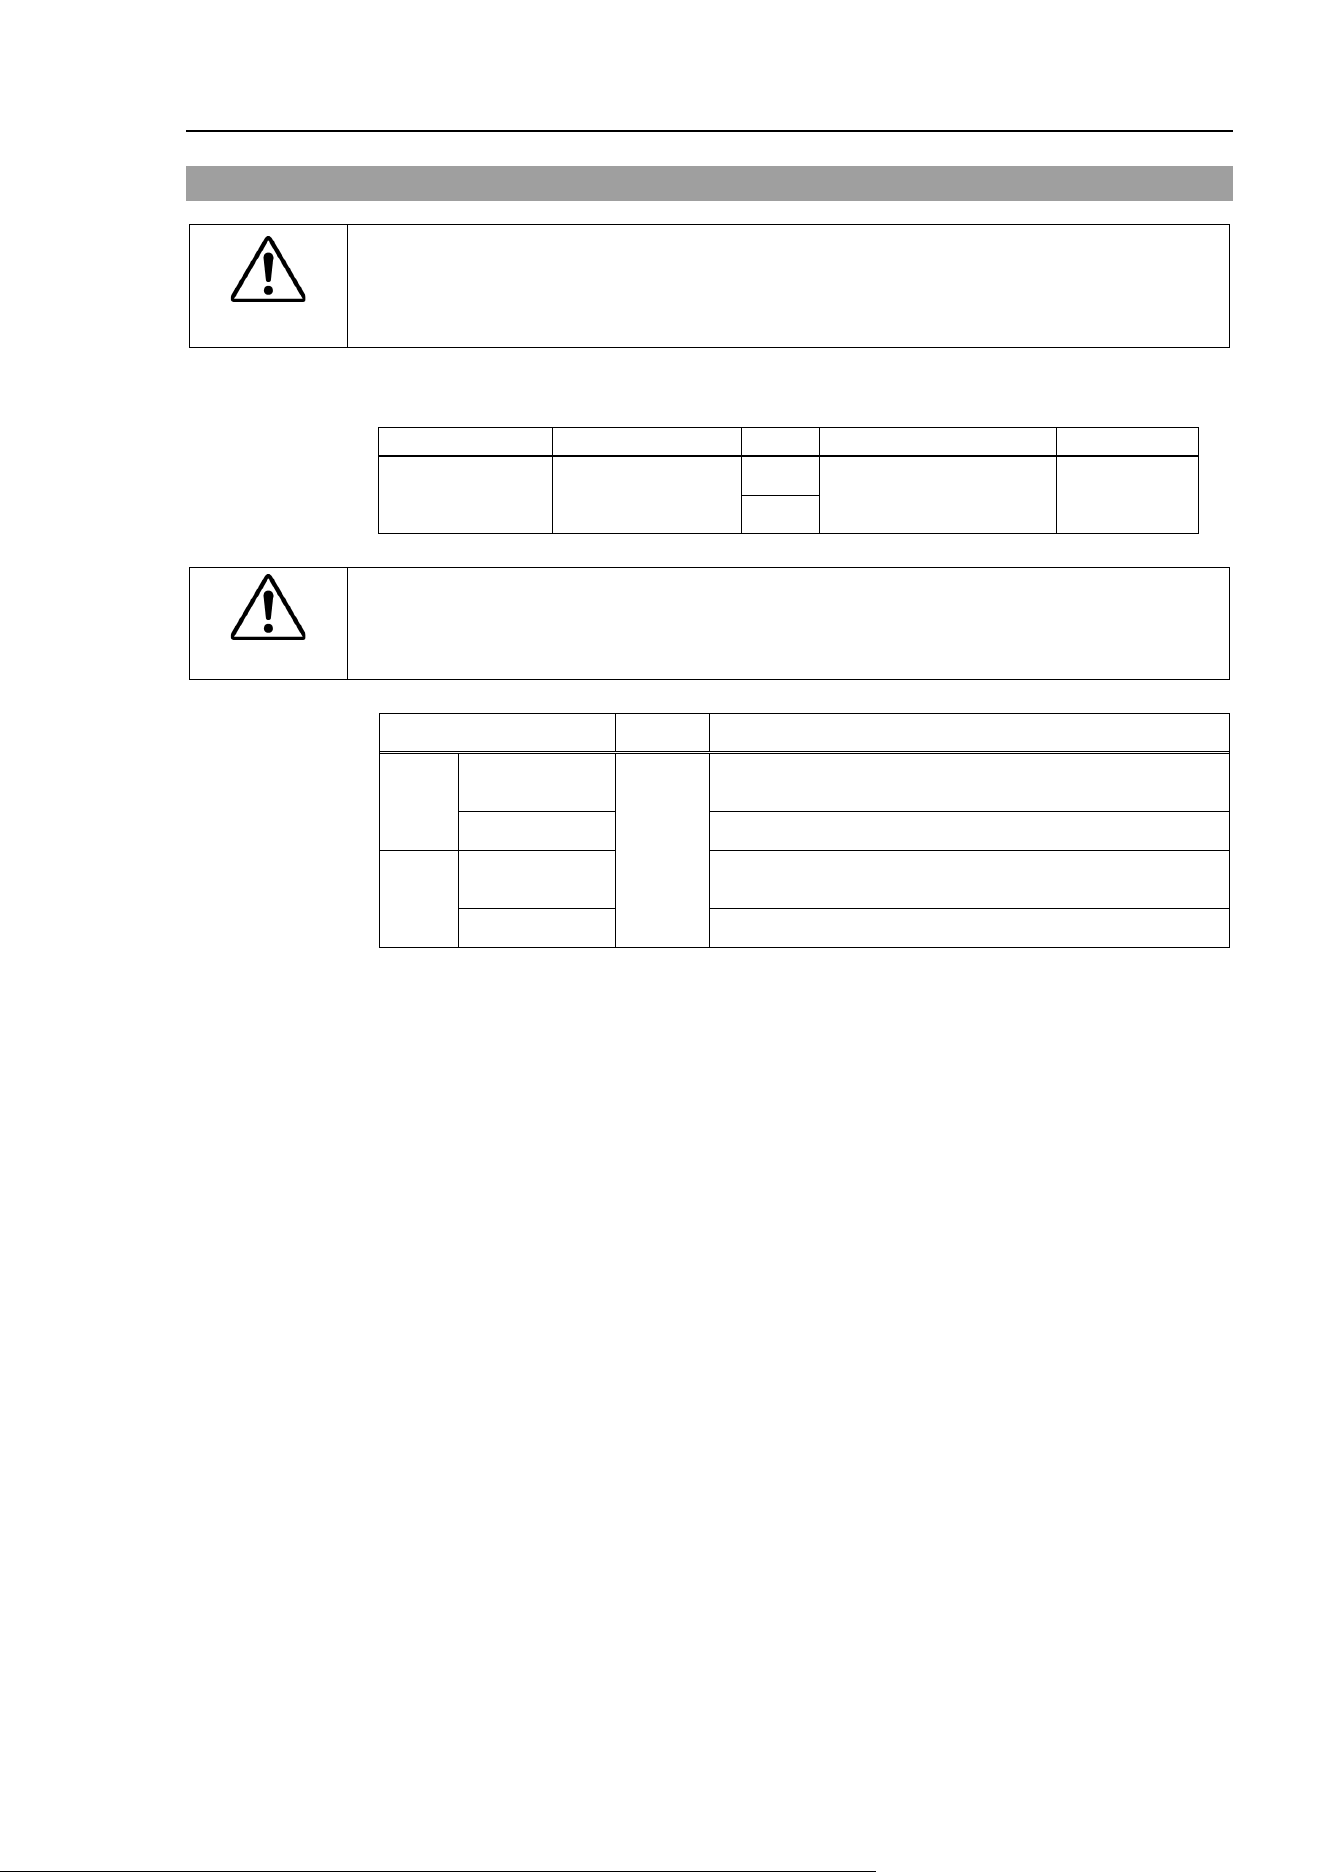
Connect the power cable and the signal connector of the M/C cable to the Controller as
shown below.
Power Connector
Signal Connector
C
onnect and disconnect M/C cable
In LS20-B series, you can connect and disconnect the M/C cable to/from the Manipulator
easily.
For details, refer to Maintenance: 4.3 Replacing M/C Cable
NOTE
Setup & Operation 3. Environments and Installation
LS20-B Rev.4 31
3.7 User Wires and Pneumatic Tubes
CAUTION
■
Only authorized or certified personnel should be allowed to perform wiring.
Wiring by unauthorized
or uncertified personnel may result in bodily injury and/or
malfunction of the robot system.
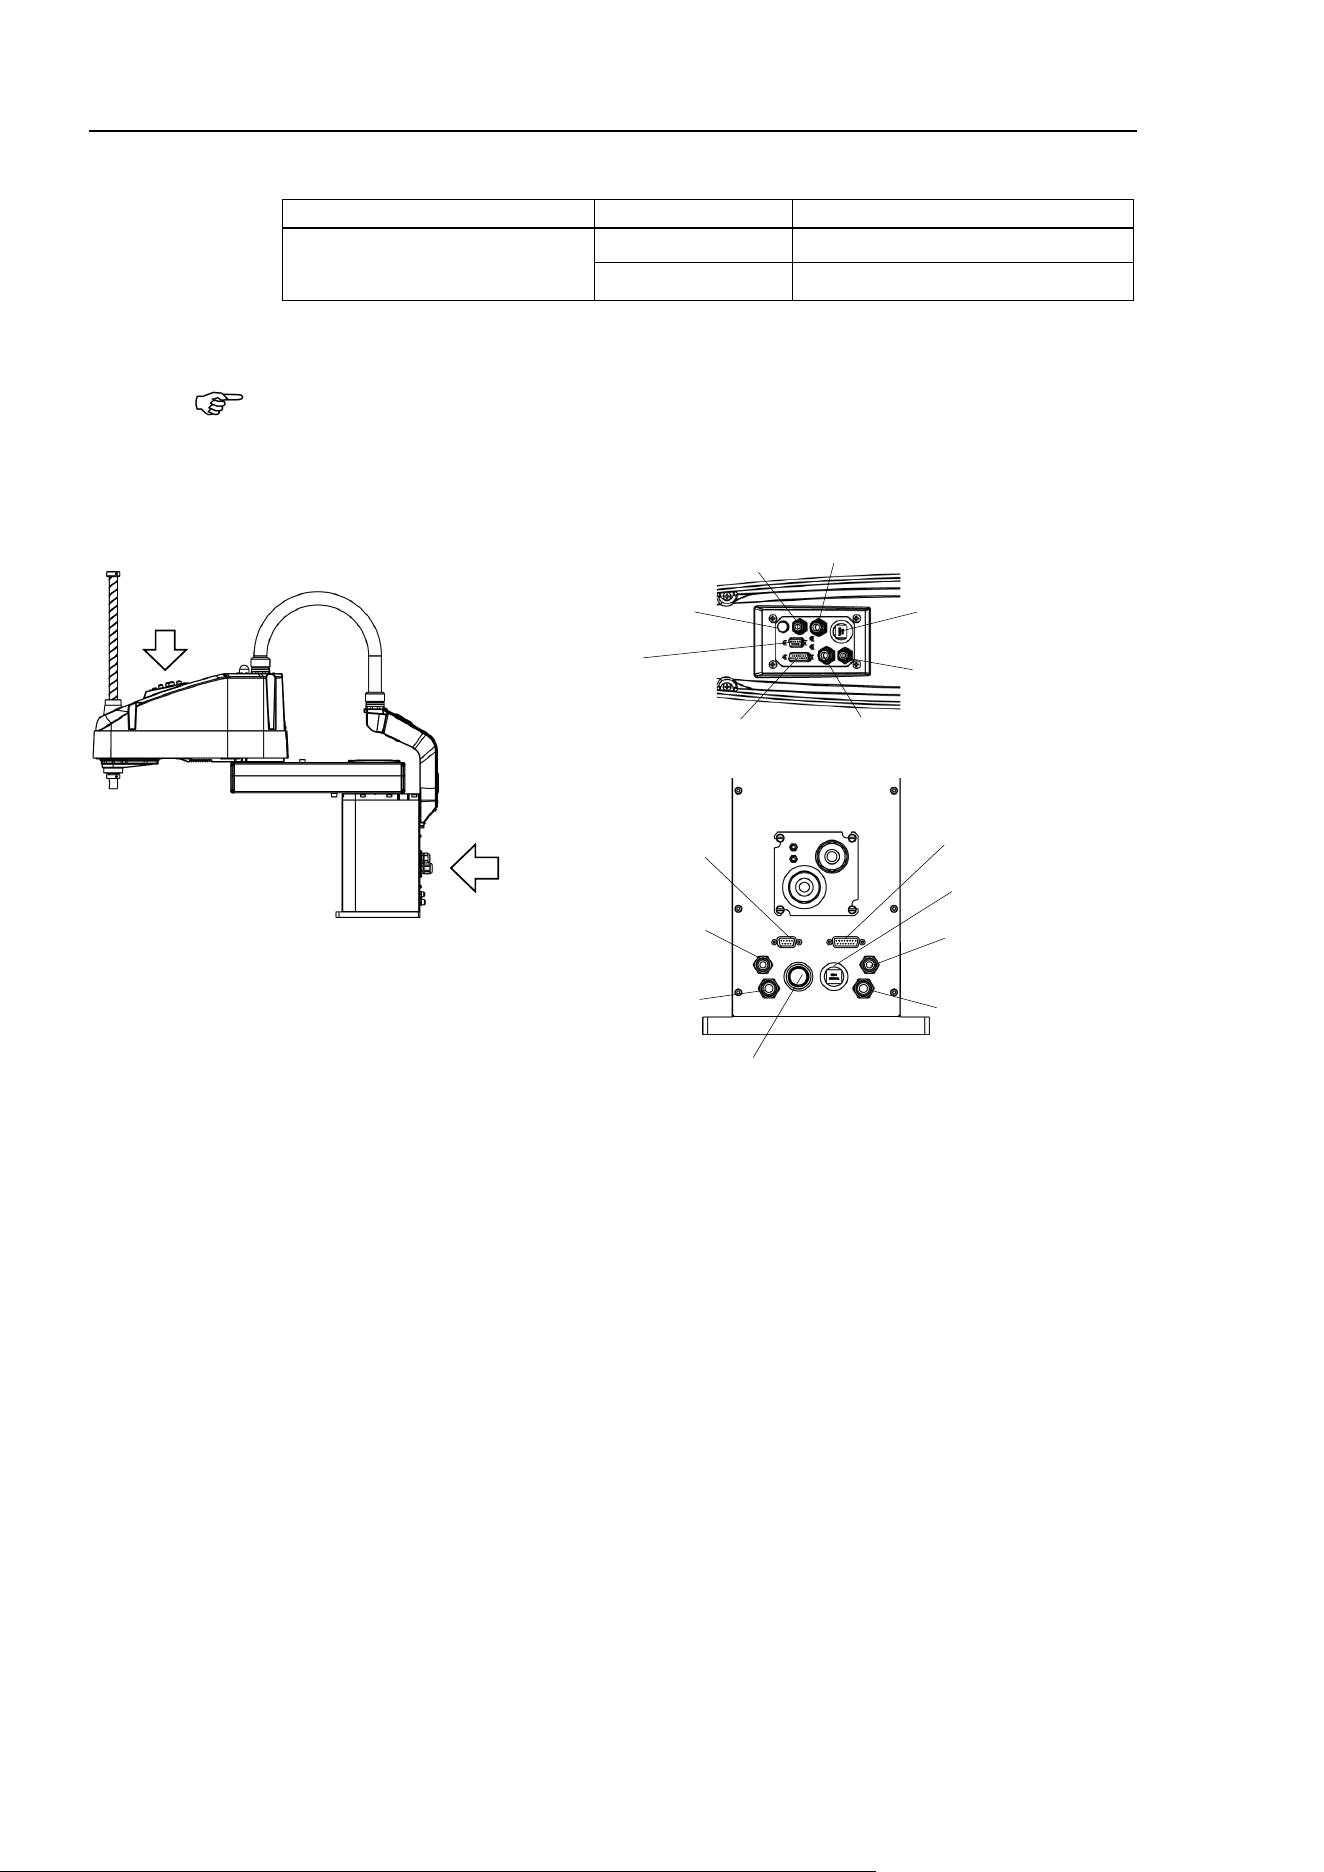
User electrical wires and pneumatic tubes are contained in the cable unit.
Electrical Wires
Rated Voltage
Allowable Current
Wires
Nominal Sectional Area
Note
AC/DC30V 1A
15
0.211 mm
2
Twist pair
Unshielded
9
WARNING
■
Do not apply the current more than 1A to the manipulator.
Mfr. Standard
15 pin
Suitable
Connector
JAE
DA-15PF-N (Solder type)
Clamp Hood
DA-C8-J10-F2-1R
(Connector setscrew : #4-40 NC)
9 pin
Suitable
Connector
DE-9PF-N (Solder type)
Clamp Hood
DE-C8-J9-F2-1R
(Connector setscrew : #4-40 NC)
Pins with the same number, indicated on the connectors on both ends of the cables, are
connected.
Setup & Operation 3. Environments and Installation
32
LS20-B Rev.4
Pneumatic Tubes
Max. Usable Pneumatic Pressure
Pneumatic Tubes
Outer Diameter × Inner Diameter
0.59 MPa (6 kgf/cm
2
: 86 psi)
2
ø6 mm
×
ø4 mm
2
ø8 mm
×
ø5 mm
Fittings for ø6 mm and ø8 mm (outer diameter) pneumatic tubes are supplied on both ends
of the pneumatic tubes.
All fittings for ø6 mm, ø8 mm pneumatic tubes of LS20-B series manipulators are white.
Be sure to check the numbers near the fittings and connect them properly.
Fitting for ø8 mm
Pneumatic Tube (No. 2)
User Connector
(15-pin D-sub Connector)
User Connector
(15-pin D-sub Connector)
Fitting for ø8 mm
Pneumatic Tube (No. 3)
Detail view from A
Detail view from B
A
B
Brake Release Switch
Exhaust Port
(Cleanroom-model Only)
Fitting for ø6 mm
Pneumatic Tube (No. 4)
EtherNet Connector
Fitting for ø6 mm
Pneumatic Tube (No. 1)
User Connector
(9-pin D-sub Connector)
Fitting for ø8 mm
Pneumatic Tube (No. 3)
Fitting for ø6 mm
Pneumatic Tube (No. 4)
Fitting for ø8 mm
Pneumatic Tube (No. 2)
Fitting for ø6 mm
pneumatic Tube (No. 1)
User Connector
(9-pin D-sub Connector)
EtherNet Connector
LS20-B804*
NOTE
Setup & Operation 3. Environments and Installation
LS20-B Rev.4 33
3.8 Relocation and Storage
3.8.1 Precautions for Relocation and Storage
Observe the following when relocating, storing, and transporting the Manipulators.
THE INSTALLATION SHALL BE PREFORMED BY QUALIFIED INSTALLATION
PERSONNEL AND SHOULD CONFORM TO ALL NATIONAL AND LOCAL CODES.
WARNING
■
Only authorized personnel
should perform sling work and operate a crane and a
forklift. When
these operations are performed by unauthorized personnel, it is
extremely
hazardous and may result in serious bodily injury and/or severe
equipment damage to the robot system.
■
Stabilize the
Manipulator with your hands when hoisting it. Unstable hoisting is
extremely hazardous and may result in serious bodily injury and/or severe
equipment damage to the robot system as the fall of the Manipulator.
CAUTION
■
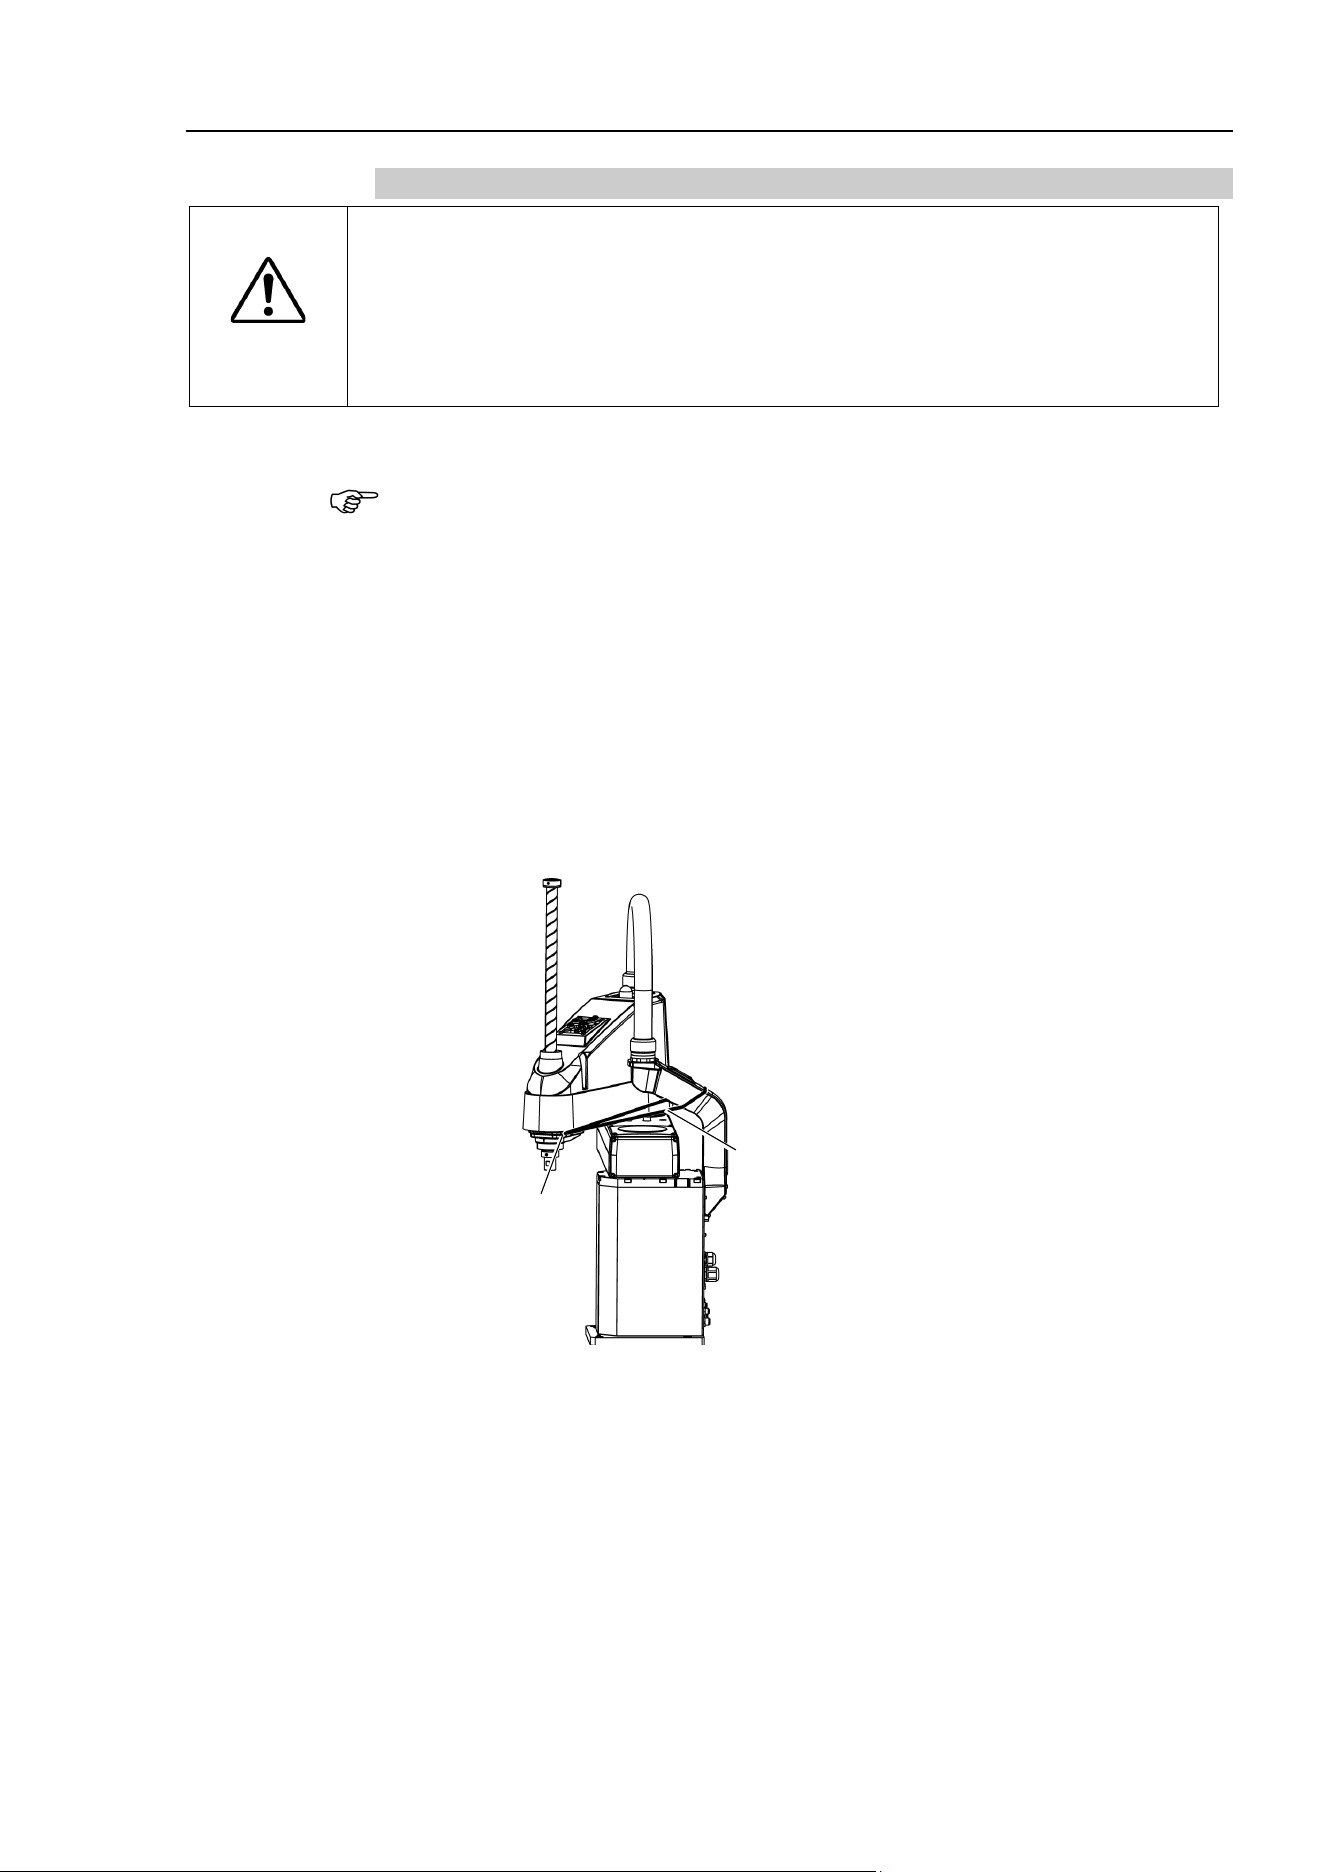
Before relocating the Manipulator,
fold the arm and secure it tightly with a wire tie
to prevent hands or fingers from
being caught in the Manipulator.
■
When removing the anchor bolts, support the Manipulator to prevent falling.
Removing the
anchor bolts without support may result in a fall of the Manipulator,
and then get hands, fingers, or feet caught.
■
To transport the Manipulator, secure it to the
delivery equipment or have at least
2 people to
hold it by hand.
Also, do not hold the bottom of the base (the
shaded area
in the figure). Holding the area by
hand is extremely hazardous and may cause your
hands and fingers caught.
LS20-B804*: approx. 48 kg: 105.8 lbs.
LS20-BA04*: approx. 51 kg: 112.5 lbs.
Metal Duct
Resin Duct
(Figure: LS20-B804S)
■
Do not hold the metal duct and the resin duct
when
transporting the Manipulator.
Doing so
may damage them.
Setup & Operation 3. Environments and Installation
34
LS20-B Rev.4
When transporting the Manipulator for a long distance, secure it to the delivery
equipment so that the Manipulator cannot fall.
If necessary, pack the Manipulator in the same way as it was delivered.
When the Manipulator is used for a robot system again after long-term storage,
perform a test run to verify that it works properly, and then operate it thoroughly.
Transport and store the Manipulator in the range of −25 °C to +55 °C.
Humidity within 10% to 90% is recommended.
When condensation occurs on the Manipulator during transport or storage, turn
ON the power only after the condensation dries.
Do not shock or shake the Manipulator during transport.
NOTE
Setup & Operation 3. Environments and Installation
LS20-B Rev.4 35
3.8.2 Relocation
CAUTION
■
Install
or relocate the Manipulator with two or more people. The
Manipulator
weigh
ts are as follows. Be careful not to get hands, fingers, or feet caught and/or
have equipment damage
d by a fall of the Manipulator.
LS20-B804* : approx. 48 kg : 105.8 lbs.
LS20-BA04* : approx. 51 kg : 112.5 lbs.
(1) Turn OFF the power on all devices and unplug the cables.
Remove the mechanical stops if using them to limit the motion range of Joints #1 and
#2. For details on the motion range, refer to Setup & Operation: 5.2 Motion Range
Setting by Mechanical Stops.
(2) Cover the arm with a sheet so that the arm will not be damaged.
Refer to the following figure and fix the arm.
Cover the arm with a sheet so that the arm will not be damaged. Insert the bolt to
the screw hole on the arm and tie the bolt with the metal duct using a string. If
fixing the arm using the shaft, fix it with adequate strength not to deform the spline.
For details on strength of the ball screw spline, refer to Setup & Operation: 1.2.1
Strength of Ball Screw Spline.
Wire tie
Bolt: M4
Example of Arm Fixed Posture
(3) Hold the bottom of Arm #1 by hand to unscrew the anchor bolts.
Then, remove the Manipulator from the base table.
NOTE
Setup & Operation 4. Setting of End Effectors
36
LS20-B Rev.4
4. Setting of End Effectors
4.1 Attaching an End Effector
Users are responsible for making their own end effector(s). Before attaching an end
effector, observe these guidelines.
CAUTION
■
If you use an end effector equipped with a gripper or chuck, connect wires and/or
pneumatic
tubes properly so that the gripper does not release the work piece
when the
power to the robot system is turned OFF. Improper connection of the
wires and/or pneuma
tic tubes may damage the robot system and/or work piece
as the work piece is released when the Emergency Stop switch is pressed.
I/O
outputs are configured at the factory so that they are automatically shut off (0)
by power disconnection, the
Emergency Stop switch, or the safety features of the
robot system
.
Shaft
-
Attach an end effector to the lower end of the shaft.
For the shaft dimensions,
and the overall dimensions of the Manipulator, refer to Setup
& Operation: 2. Specifications.
-
Do not move the upper limit mechanical stop on the lower side of the shaft.
Otherwise, when
“Jump motion”
is performed, the upper limit mechanical stop may hit
the Manipulator, and the robot system may not function properly.
-
Use a split muff coupling with an M4 bolt or larger to attach the end effector to the
shaft.
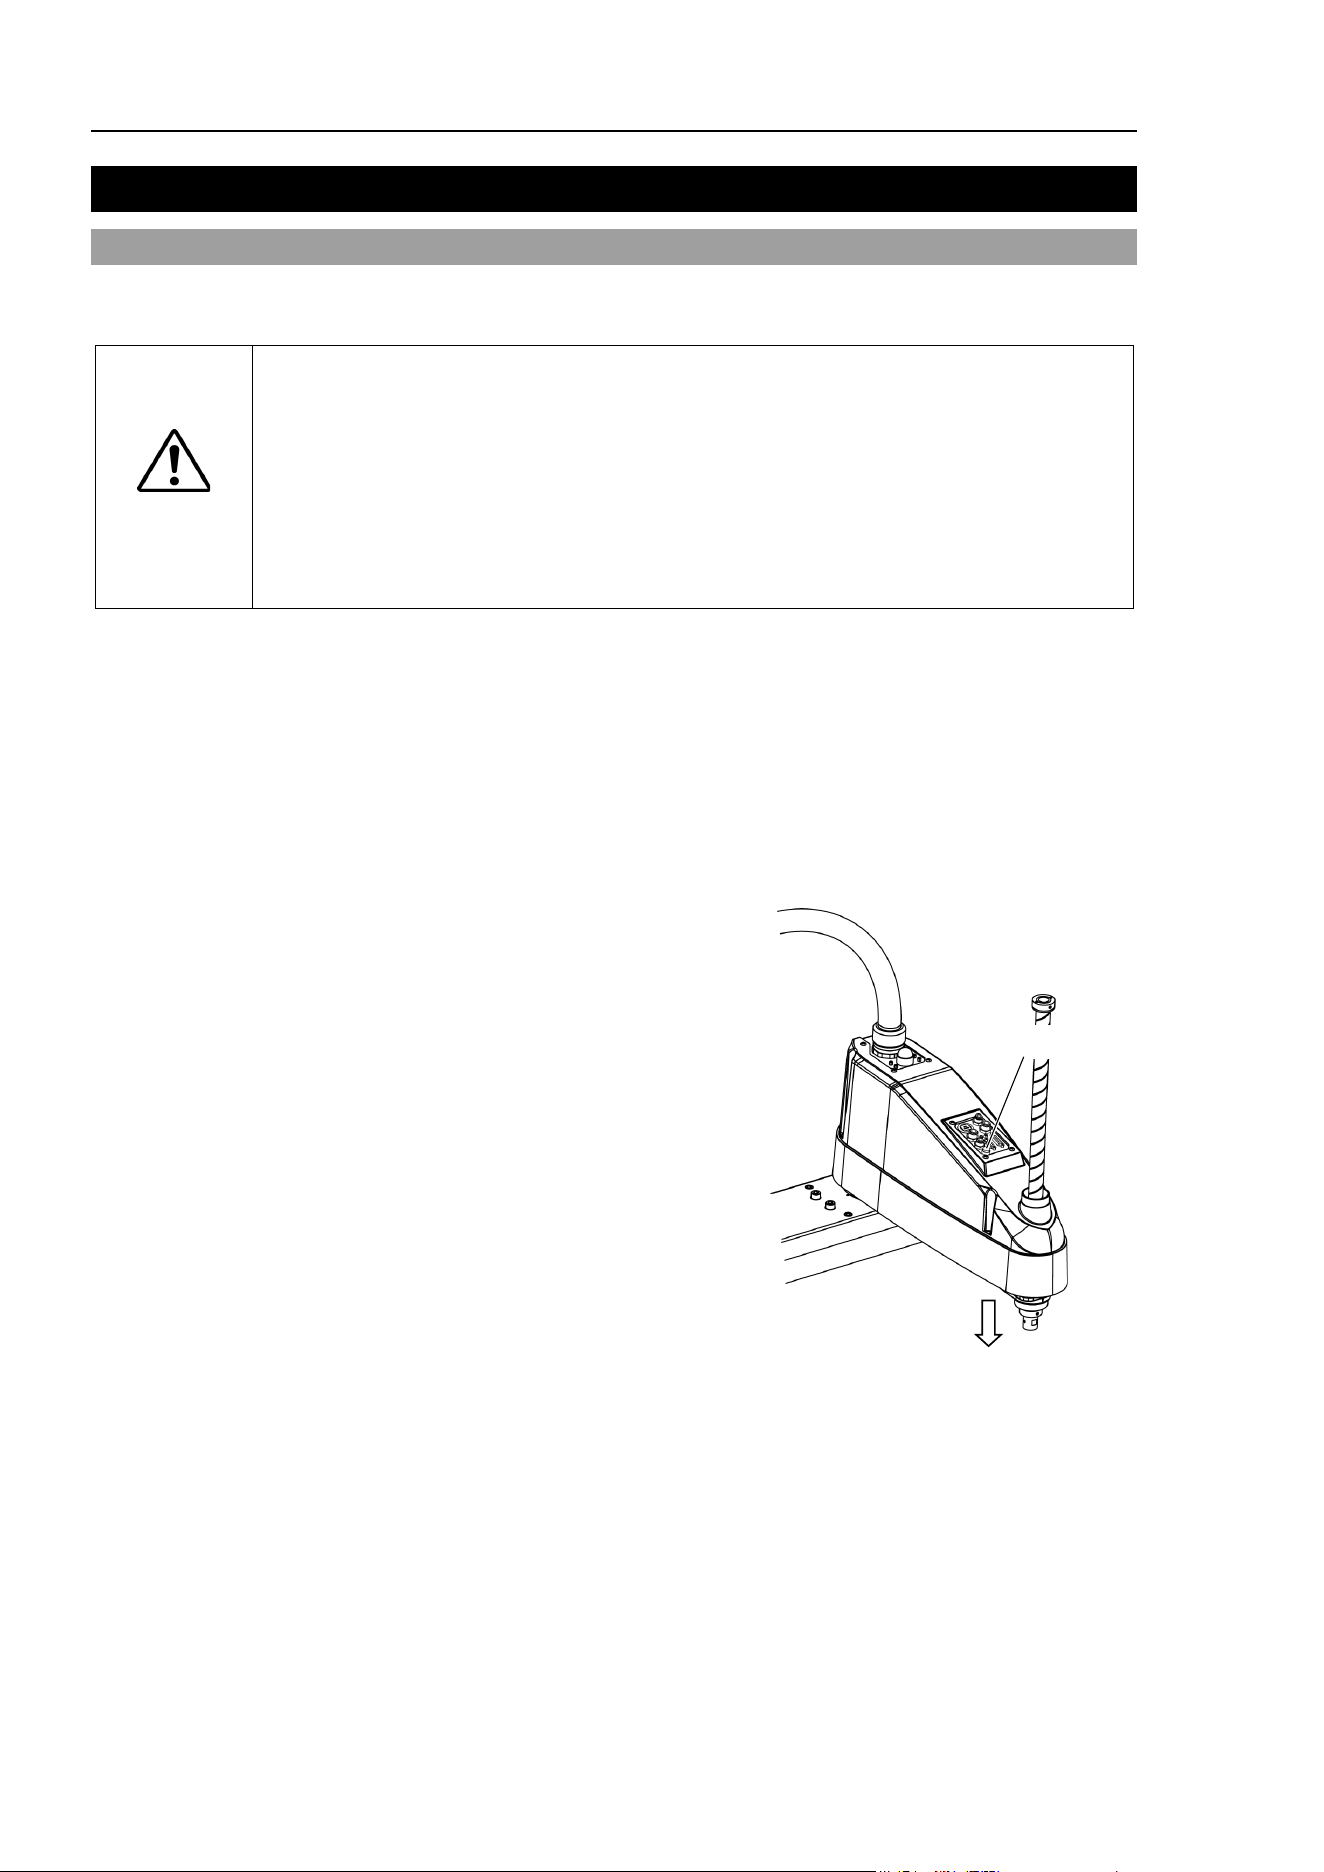
Brake release switch
-
Joint #3 and #4 cannot be moved up/down by
hand because the electromagnetic brake is
applied to the joint while power
to the robot
system
is turned OFF.
This prevents the shaft f
rom hitting peripheral
equipment in the case that the shaft is lowered
by the weight of the end effector when the
power
is disconnected during operation, or
when the motor is turned OFF even though the
power
is turned ON.
To move Joint #3 up/down or
rotate Joint #4
while attaching an end effector
, turn ON the
C
ontroller and move the joint up/down or
rotate the joint while pressing
the brake
release
switch
.
This button
switch is a momentary-type; the
brake is released only wh
ile the button switch
is being pressed
Brake release switch
Shaft may be lowered by the weight
of the end effector.
-
Be careful of the shaft while the brake release
switch
is being pressed because the shaft may
be lowered by the weight of the end effector.
Layouts
-
When you operate the manipulator with an end effector, the end effector may interfere
with
the Manipulator because of the outer diameter of the end effector, the size of the
work piece
, or the position of the arms. When designing your system layout, pay
attention to the interference area of the end effector.
Setup & Operation 4. Setting of End Effectors
LS20-B Rev.4 37
4.2 Attaching Cameras and Valves
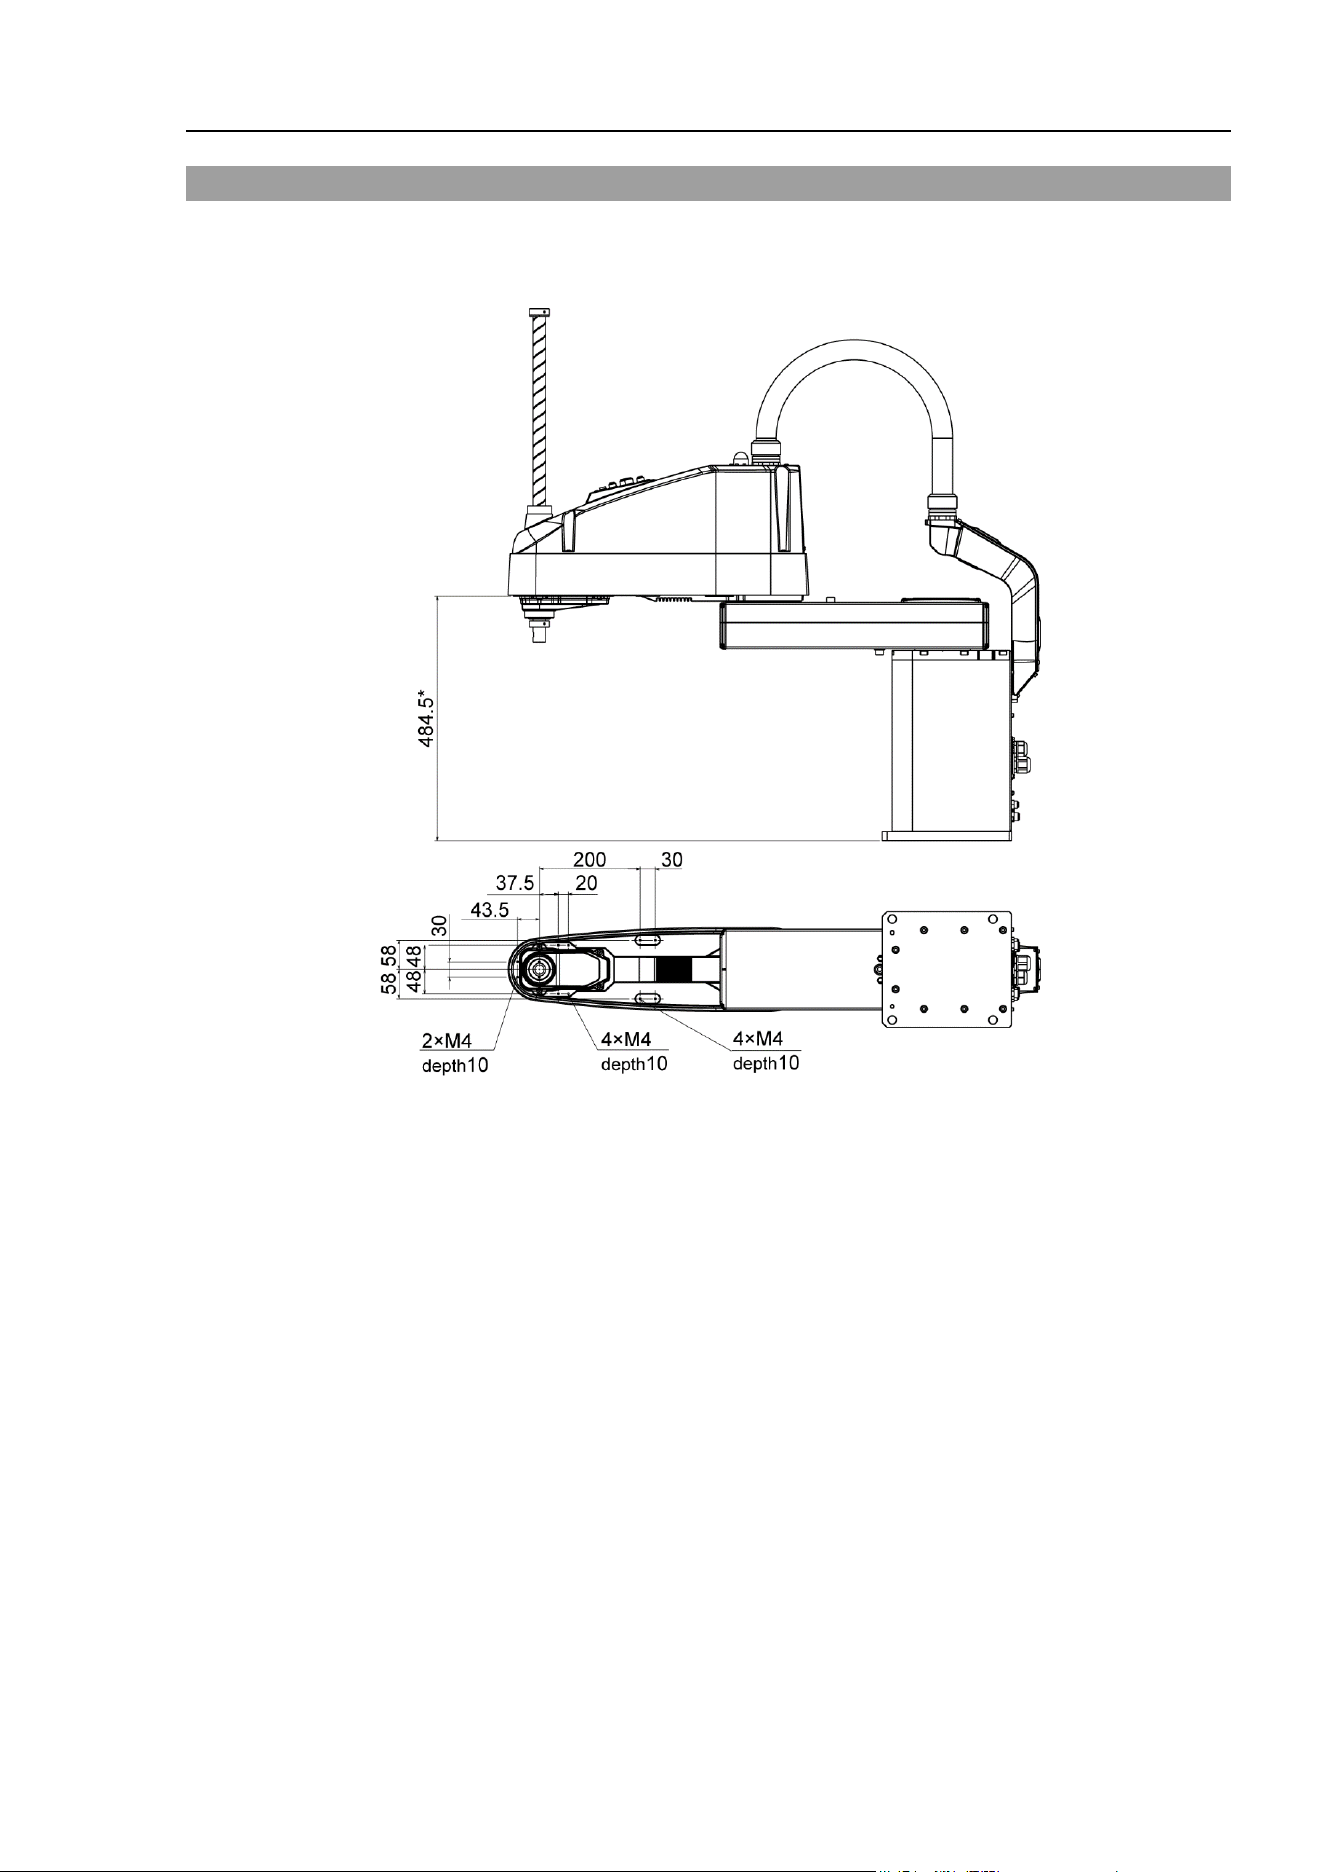
The bottom of the Arm #2 has threaded holes as shown in the figure below. Use these
holes for attaching cameras, valves, and other equipment.
[Unit: mm]
*: From base installation surface
Setup & Operation 4. Setting of End Effectors
38
LS20-B Rev.4
4.3 Weight and Inertia Settings
To ensure optimum Manipulator performance, it is important to make sure that the load
(weight of the end effector and work piece) and moment of inertia of the load are within the
maximum rating for the Manipulator, and that Joint #4 does not become eccentric.
If the load or moment of inertia exceeds the rating or if the load becomes eccentric, follow
the steps below, “4.3.1 Weight Setting” and “4.3.2 Inertia Setting” to set parameters.
Setting parameters makes the PTP motion of the Manipulator optimal, reduces vibration to
shorten the operating time, and improves the capacity for larger loads. In addition, it
reduces persistent vibration produced when the moment of inertia of the end effector and
work piece is larger than the default setting.
4.3.1 Weight Setting
CAUTION
■
The total weight o
f the end effector and the workpiece must not exceed 20 kg
.
The
LS20-B series Manipulators are not designed to work with loads exceeding
2
0 kg. Always set the Weight parameters according to the load. Setting a value
that is smaller than the actual load may cause errors, excessive shock and
insufficient function of the Manipulator.
Also, the life cycle of parts will shorten
and belt tooth jumping will occur which will lead to potion shift.
The acceptable weight capacity (end effector and workpiece) in LS20-B series is
Default rating: 10 kg
Maximum: 20 kg
When the load (weight of the end effector and work piece) exceeds the rating, change the
setting of Weight parameter.
After the setting is changed, the maximum acceleration/deceleration speed of the robot
system at PTP motion corresponding to the “Weight Parameter” is set automatically.
Load on the Shaft
The load (weight of the end effector and work piece) on the shaft can be set by Weight
parameter.
EPSON
RC+
Enter a value into the [Load inertia:] text box on the [Inertia] panel (
[Tools]-
[Robot
M
anager]). (You may also execute the Inertia command from the [Command Window].)
Setup & Operation 4. Setting of End Effectors
LS20-B Rev.4 39
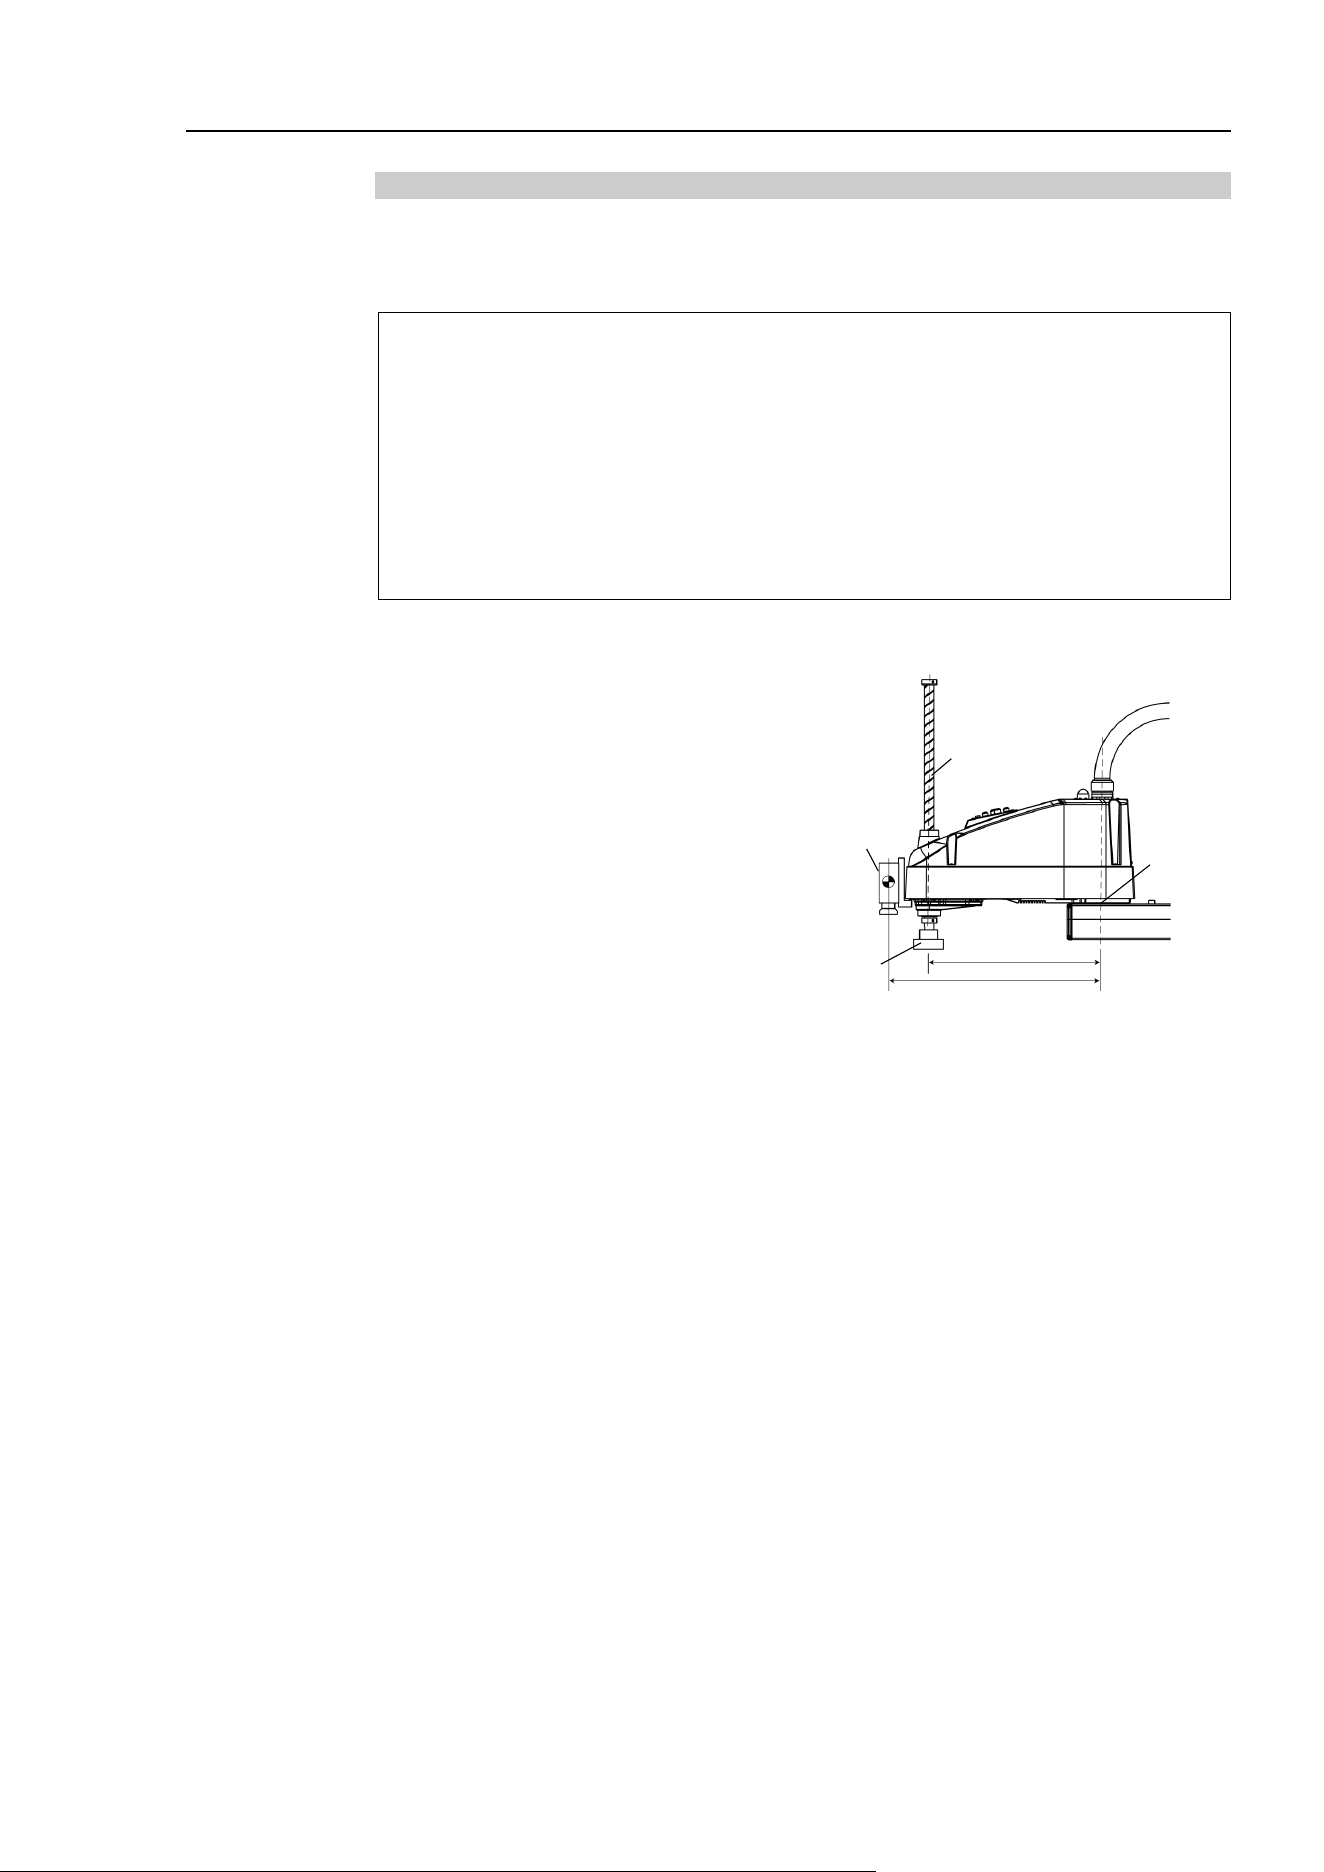
Load on the Arm
When you attach a camera or other devices to the arm, calculate the weight as the equivalent
of the shaft. Then, add this to the load and enter the total weight to the Weight parameter.
Equivalent Weight Formula
When you attach the equipment near
Arm #2:
When you attach the equipment to the end of Arm #2:
W
M
= M (L
1
)
2
/(L
1
+L
2
)
2
W
M
= M (L
M
)
2
/(L
2
)
2
W
M
M
L
1
L
2
L
M
:
equivalent weight
:
weight of camera etc.
:
length of Arm #1
:
length of Arm #2
:
distance from rotation center of Joint #2 to center of gravity
of camera etc.
<Example>
A
“1 kg” camera is attached to the end of the LS20-B series arm (550
mm away from
the rotation center of Joint #2) with a load weight of “1 kg”.
M=1
L
2
=450
L
M
=550
W
M
=1×550
2
/450
2
=1.494
→ 1.5 (round up)
W+W
M
=1+1.5=2.5
Enter
“2.5” for the Weight Parameter.
Shaft
Weight of
camera
M=1kg
W=1kg
L
2
=450 mm
L
M
=550 mm
Joint #2
Setup & Operation 4. Setting of End Effectors
40
LS20-B Rev.4
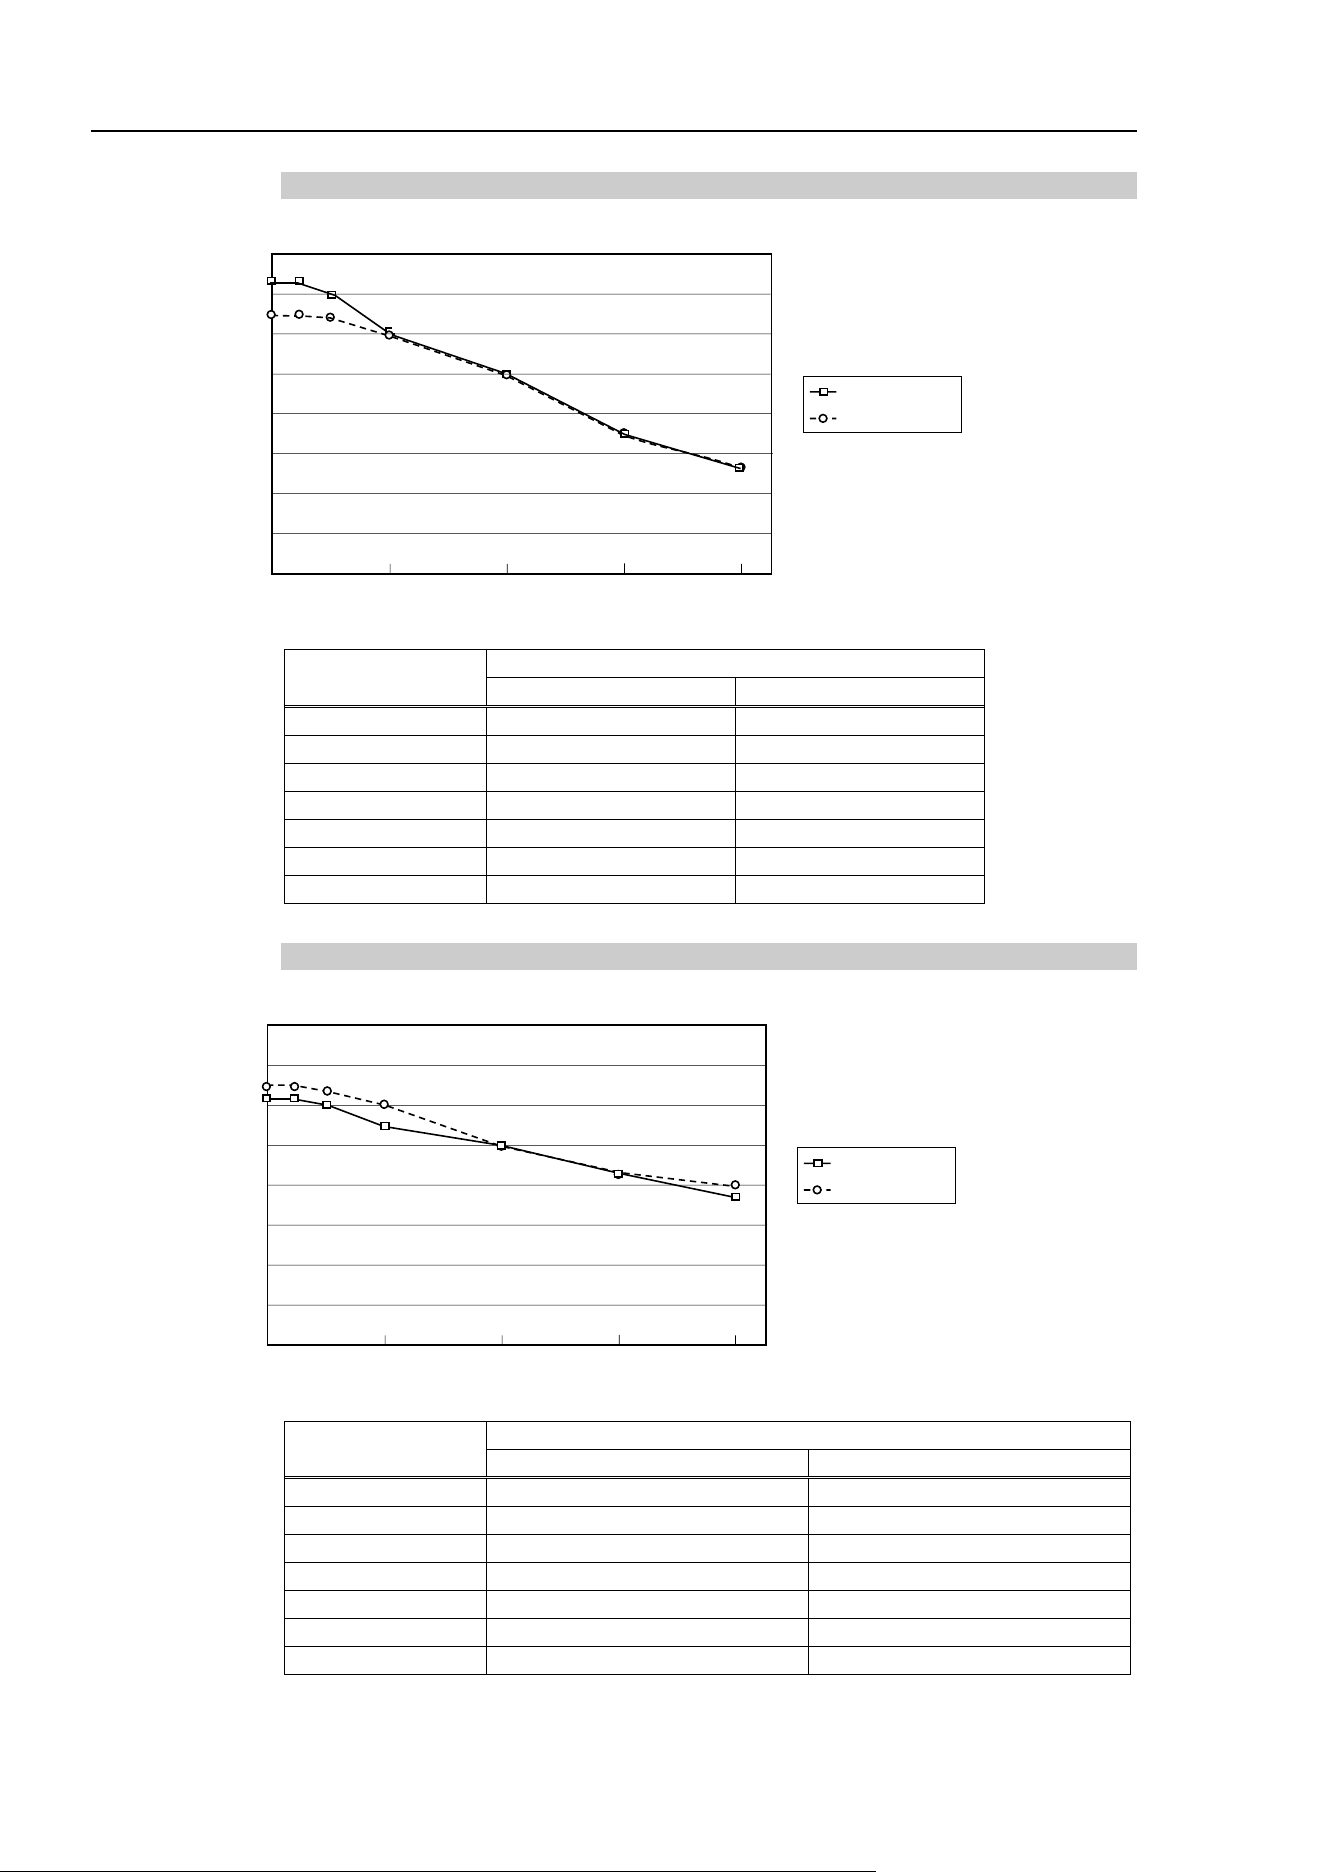
Automatic speed setting by Weight
50
55
130
128
140
LS20-BA04*
LS20-B804*
* The percentage in the graph is based
on the acceleration/ deceleration at
rated weight (10 kg) as 100%.
70
145
120
100
(%)
160
140
120
100
80
60
40
20
0
5
10 15 20 (kg) Weight setting
55
End effector
weight (kg)
Automatic speed setting by Weight (%)
LS20-B804*
LS20-BA04*
0
130
145
1
130
145
2
128
140
5
120
120
10
100
100
15
70
70
20
55
55
Automatic acceleration/deceleration setting by Weight
160
140
120
100
80
60
40
20
(%)
LS20-BA04*
LS20-B804*
* The percentage in the graph is based
on the acceleration/ deceleration at
rated weight (10
kg)
as 100%.
0 5 10 15 20 (kg) Weight setting
130
110
100
86
128
125
75
120
80
120
End effector
weight (kg)
Automatic acceleration/deceleration setting by Weight (%)
LS20-B804*
LS20-BA04*
0
130
125
1
130
125
2
128
120
5
120
110
10
100
100
15
86
86
20
80
75
Setup & Operation 4. Setting of End Effectors
LS20-B Rev.4 41
4.3.2 Inertia Setting
Moment of Inertia and the Inertia Setting
The moment of inertia is defined as “the ratio of the torque applied to a rigid body and its
resistance to motion”. This value is typically referred to as “the moment of inertia”,
“inertia”, or “GD
2
”. When the Manipulator operates with additional objects (such as an
end effector) attached to the shaft, the moment of inertia of load must be considered.
CAUTION
■
The
moment of inertia of the load (weight of the end effector and workpiece) must
be
1.0 kg·m
2
or less. The LS20-B series Manipulators are not designed to work
with
a moment of inertia exceeding 1.0 kg·m
2
.
Always set the Weight parameters according to the load. Setting a value that is
smaller than the actual load may cause errors, excessive
shock and insufficient
function of the Manipulator. Also, the life cycle of parts is shortened and
positional
gap due to belt tooth bumping occurs.
The acceptable moment of inertia of load for a LS20-B series Manipulator is
Default rating: 0.05 kg·m
2
Maximum: 1.00 kg·m
2
When the moment of inertia of the load exceeds the rating, change the setting of the moment
of inertia parameter of the Inertia command. After the setting is changed, the maximum
acceleration/deceleration speed of Joint #4 at PTP motion corresponding to the “moment of
inertia” value is set automatically.
Setup & Operation 4. Setting of End Effectors
42
LS20-B Rev.4
Moment of inertia of load on the shaft
The moment of inertia of load (weight of the end effector and work piece) on the shaft can
be set by the “moment of inertia” parameter of the Inertia command.
EPSON
RC+
Enter a value into the [Load inertia:] text box on the [Inertia] panel (
[Tools]-
[Robot
M
anager]). (You may also execute the Inertia command from the [Command Window].)
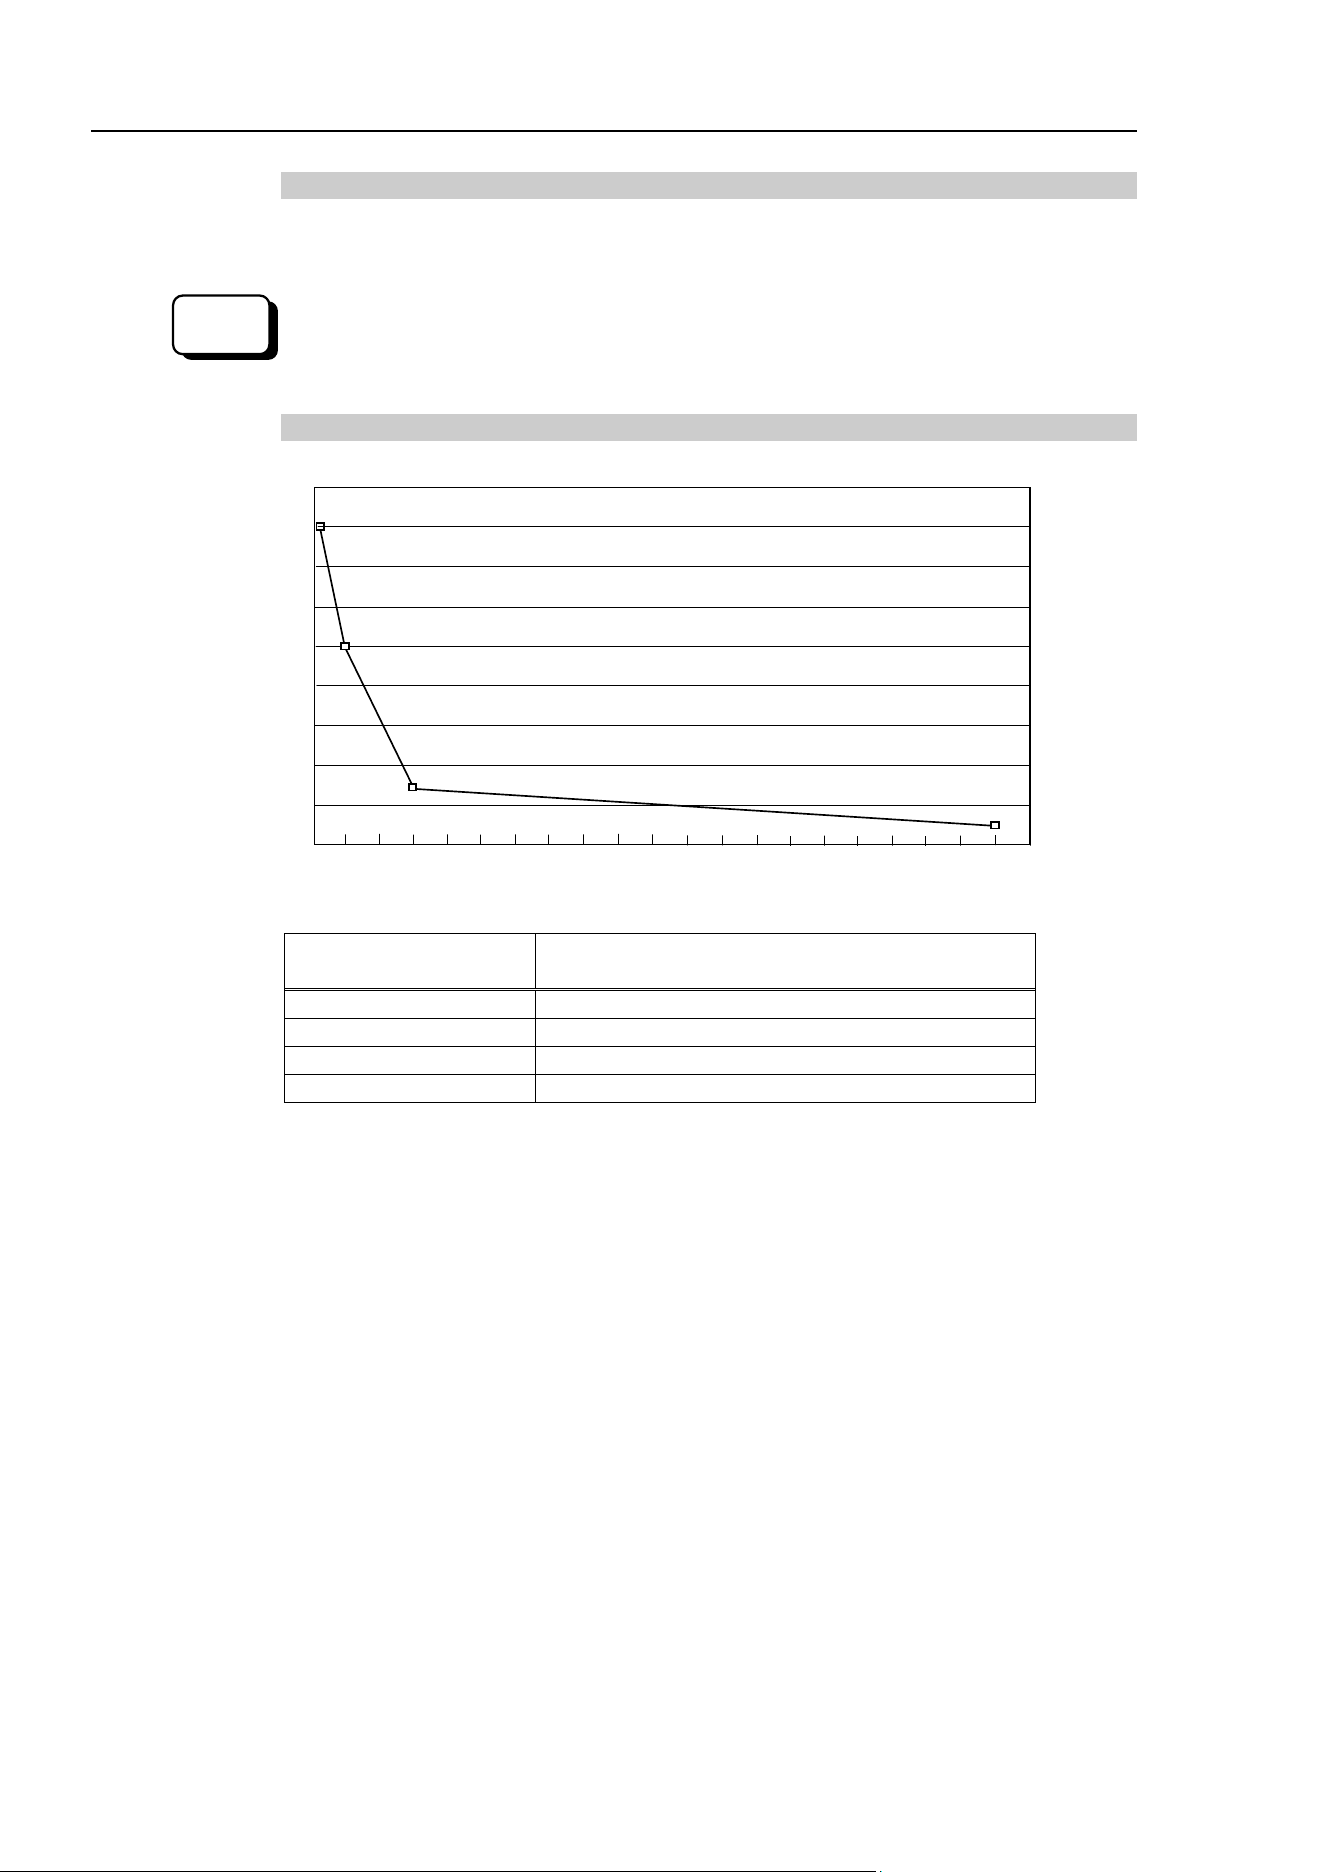
Automatic acceleration/deceleration setting of Joint #4 by Inertia (moment of inertia)
0 0.10 0.20 0.30 0.40 0.50 0.60 0.70 0.80 0.90 1.00 (kg·m
2
)
Moment of inertia setting
180
160
140
120
100
80
60
40
20
(%)
160
28.6
7.1
100
Moment of inertia
setting (kg·m
2
)
Automatic acceleration/deceleration setting of
Joint #4 by Inertia (moment of inertia) (%)
0.01
160
0.05
100
0.15
28.6
1.00
7.1
Setup & Operation 4. Setting of End Effectors
LS20-B Rev.4 43
Eccentric Quantity and the Inertia Setting
CAUTION
■
The
eccentric quantity of load (weight of the end effector and workpiece) must be
200 mm
or less. The LS20-B series Manipulators are not designed to work with
eccentric quantity
exceeding 200 mm.
Always set the Weight parameters according to the load. Settin
g a value that is
smaller than the actual load may cause errors, excessive shock and insufficient
function of the Manipulator. Also, the life cycle of parts is shortened and
positional
gap due to belt tooth bumping occurs.
The acceptable eccentric quantity of load in LS20-B series is 0 mm at the default rating and
200 mm at the maximum. When the eccentric quantity of load exceeds the rating, change
the setting of eccentric quantity parameter of Inertia command. After the setting is
changed, the maximum acceleration/deceleration speed of the Manipulator at PTP motion
corresponding to the “eccentric quantity” is set automatically.
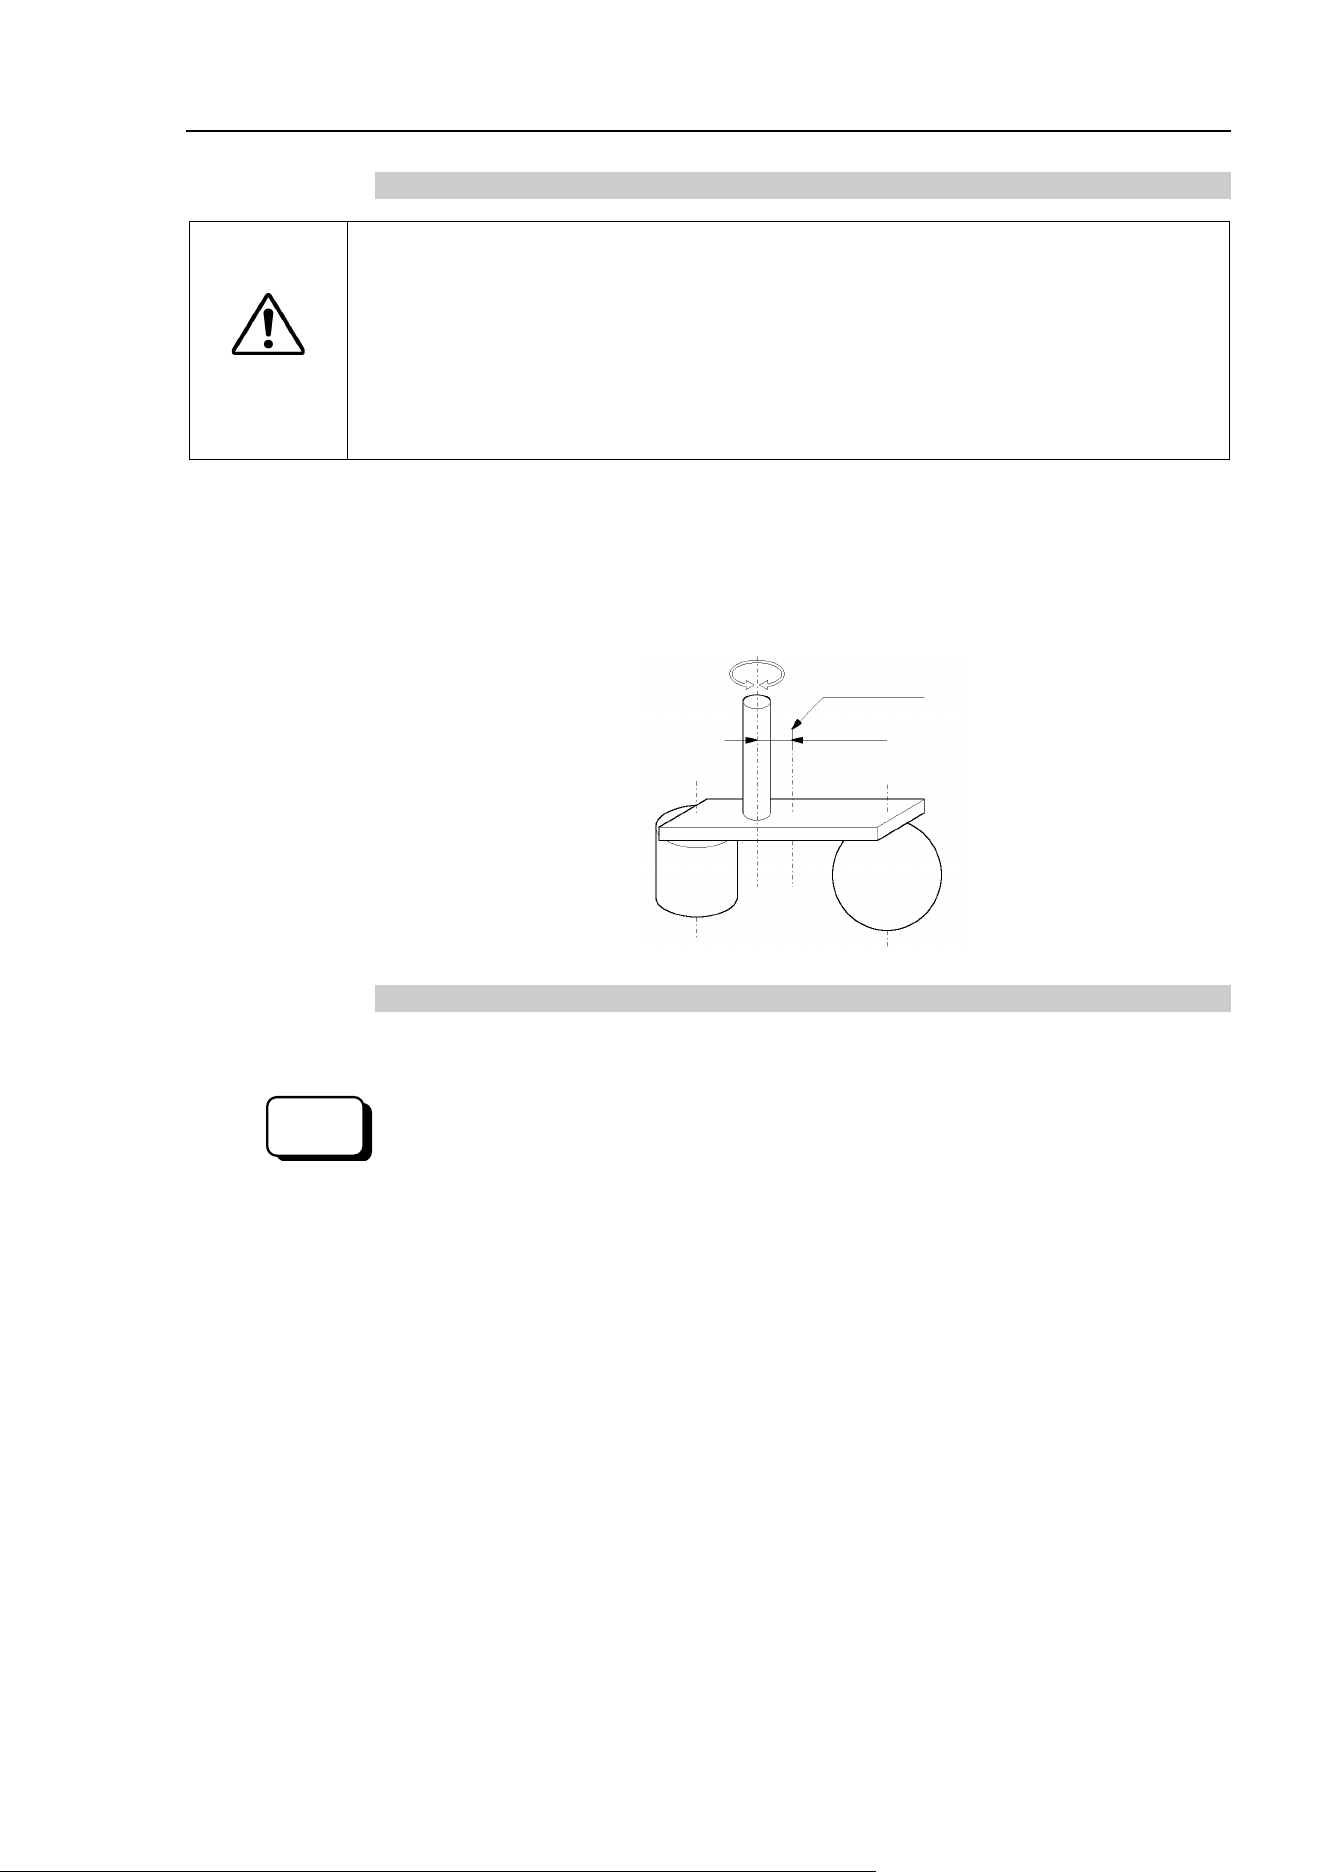
Position of load’s center of gravity
Rotation center
Eccentric quantity (200mm or less)
Eccentric Quantity
Eccentric quantity of load on the shaft
The eccentric quantity of load (weight of the end effector and work piece) on the shaft can
be set by “eccentric quantity” parameter of Inertia command.
EPSON
RC+
Enter a value into the [Eccentricity:] text box on the
[Inertia] panel ([Tools]-
[Robot
M
anager]). (You may also execute the Inertia command from the [Command Window].)
Setup & Operation 4. Setting of End Effectors
44
LS20-B Rev.4
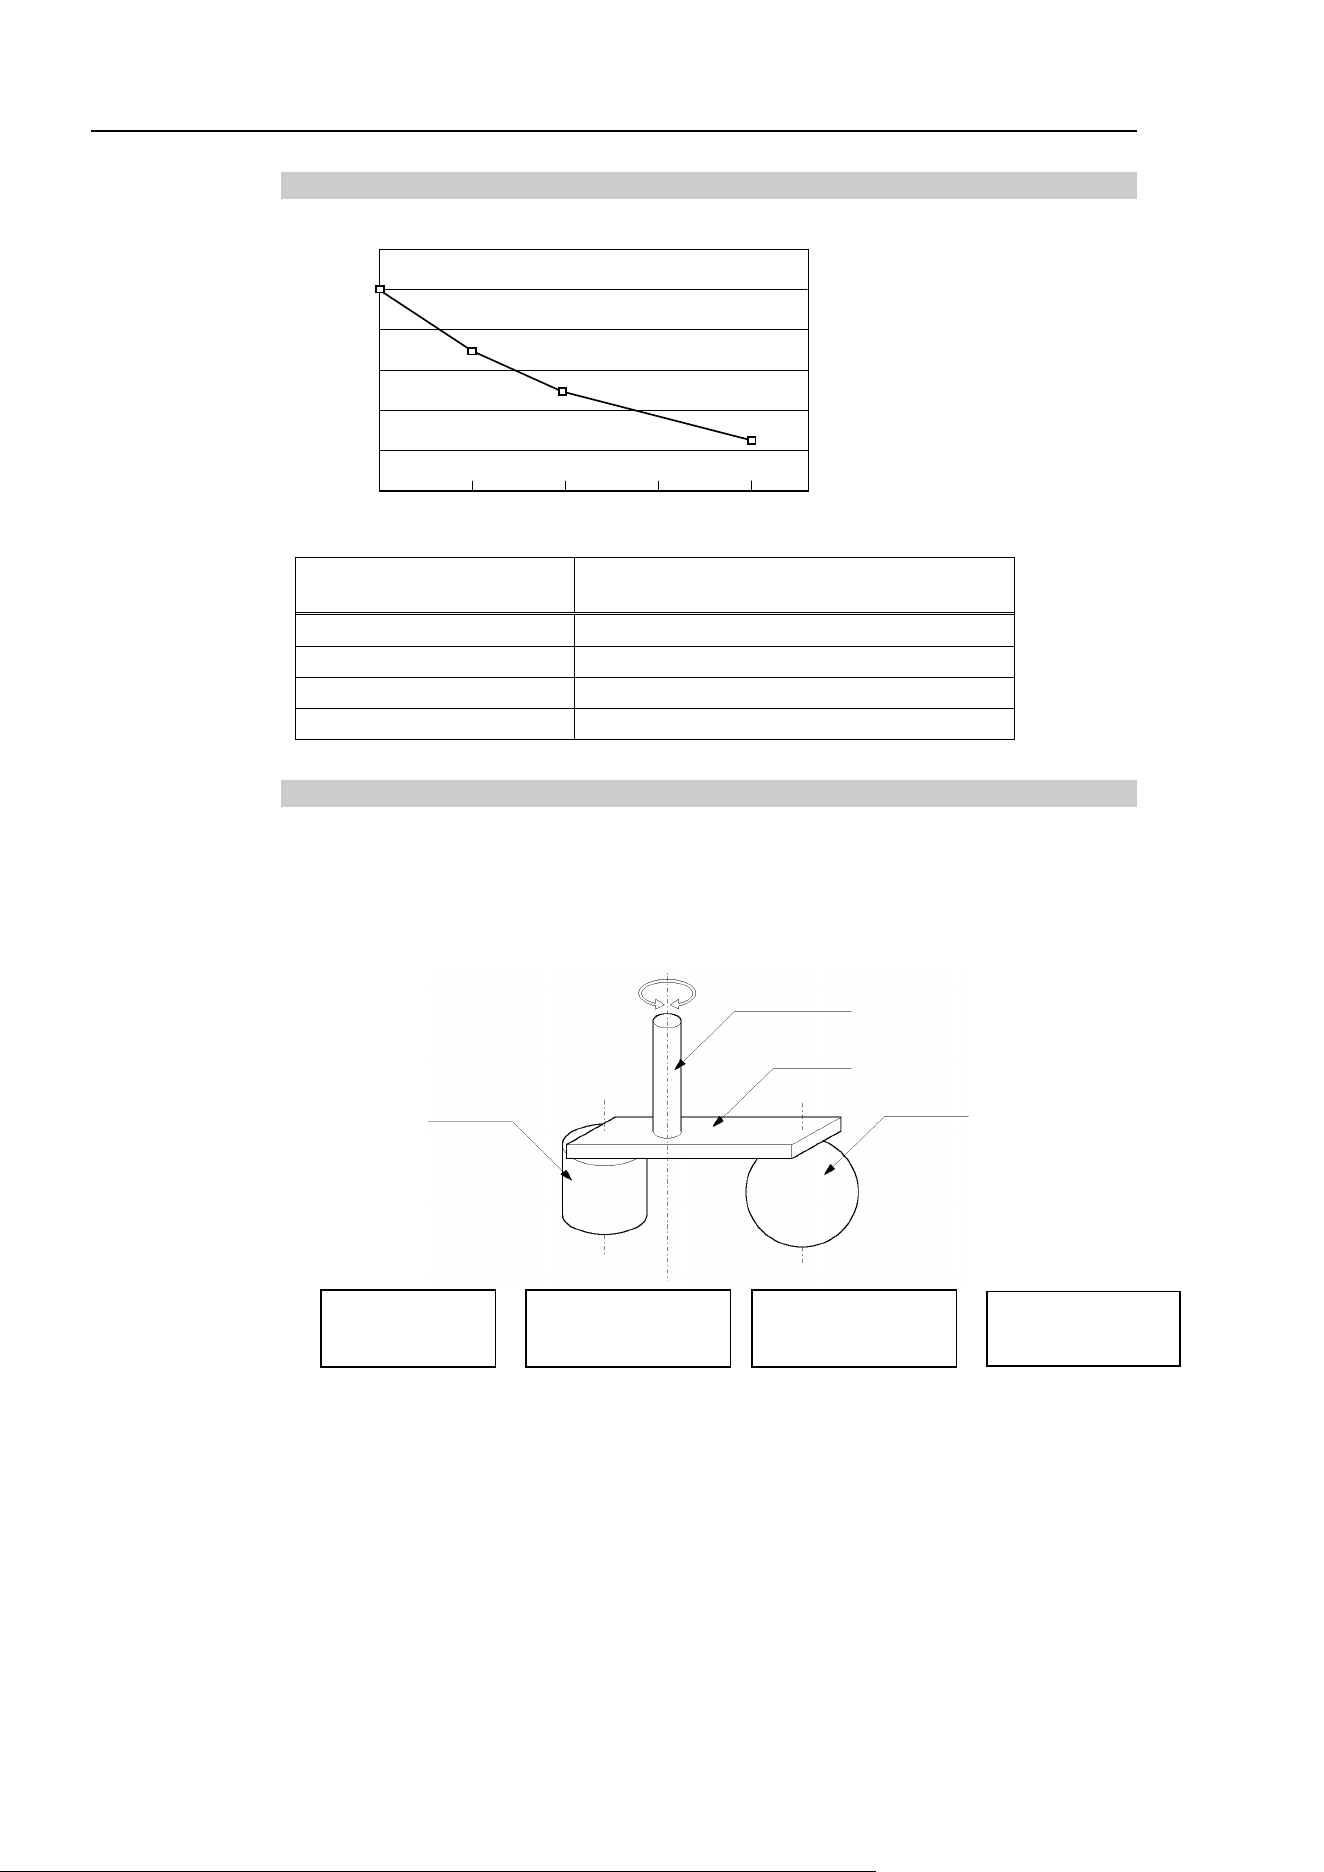
Automatic acceleration/deceleration setting by Inertia (eccentric quantity)
* The percentage in the
graph is based on the
acceleration / deceleration
at rated eccentricity
(0 mm) as 100%.
120
100
80
60
40
20
0 50 100 150 200 (mm)
Eccentricity setting
70
50
25
(%)
100
Eccentric quantity
parameter (mm)
Automatic acceleration/deceleration
setting by Inertia (eccentric quantity) (%)
0
100
50
70
100
50
200
25
Calculating the Moment of Inertia
Refer to the following examples of formulas to calculate the moment of inertia of load (end
effector with work piece). The moment of inertia of the entire load is calculated by the
sum of each part (a), (b), and (c).
Workpiece (b)
Workpiece (c)
End effector (a)
Joint #3 shaft
Rotation center
Whole moment
of inertia
Moment of inertia
of end effector (a)
= +
Moment of inertia
of work piece (c)
+
Moment of inertia
of work piece (b)
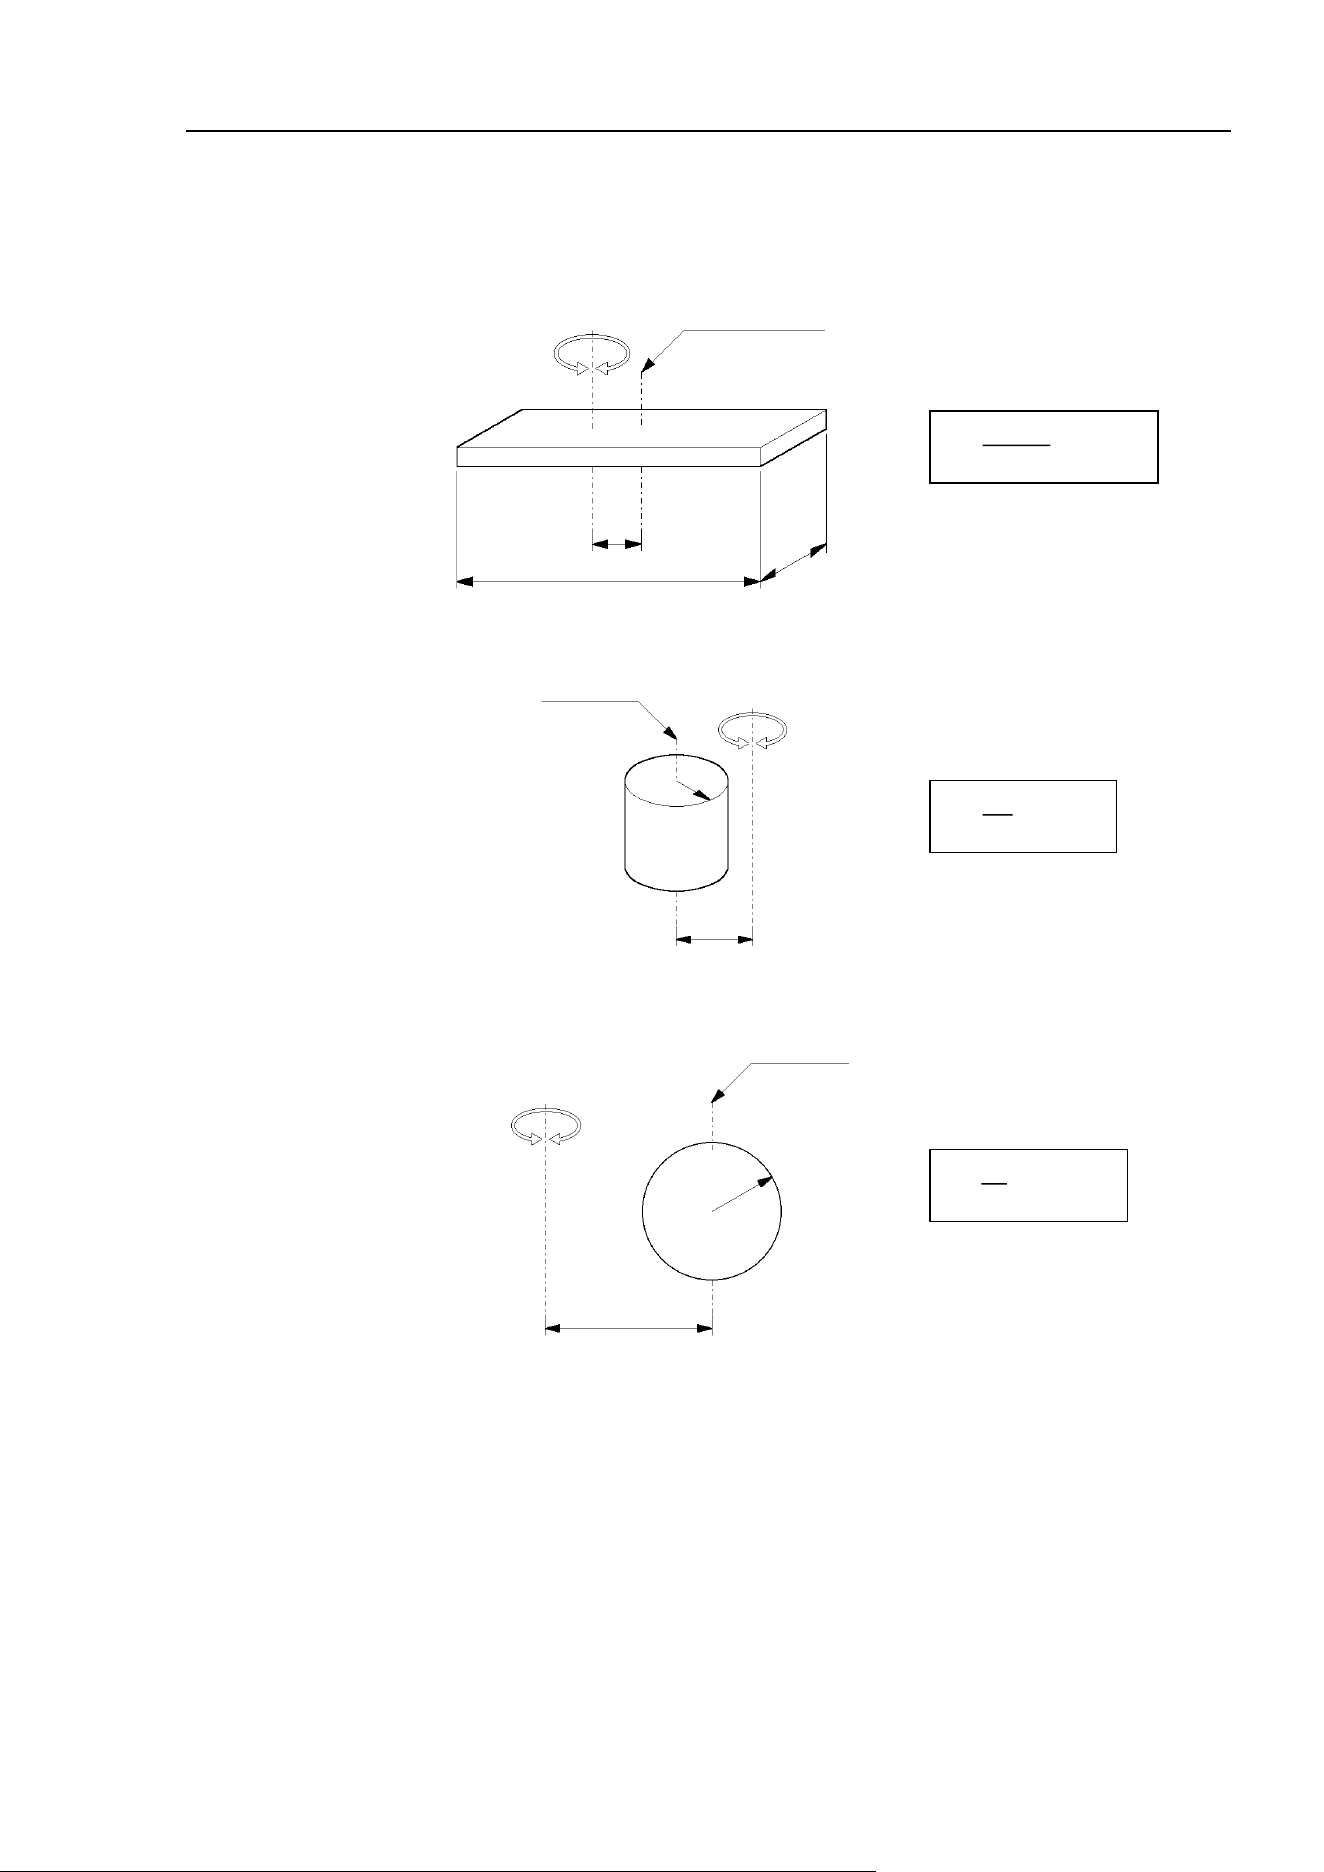
Setup & Operation 4. Setting of End Effectors
LS20-B Rev.4 45
The methods for calculating the moment of inertia for (a), (b), and (c) are shown below.
Calculate the total moment of inertia using the basic formulas.
(a) Moment of inertia of a rectangular parallelepiped
h
b
L
m
Rectangular parallelepiped’s center of gravity
Rotation center
m
+ m × L
2
b
2
+ h
2
12
(b) Moment of inertia of a cylinder
m
+ m × L
2
r
2
2
m
L
r
Cylinder’s center of gravity
Rotation center
(c) Moment of inertia of a sphere
m
r
2
+ m × L
2
2
5
Sphere’s center of gravity
r
m
L
Rotation center
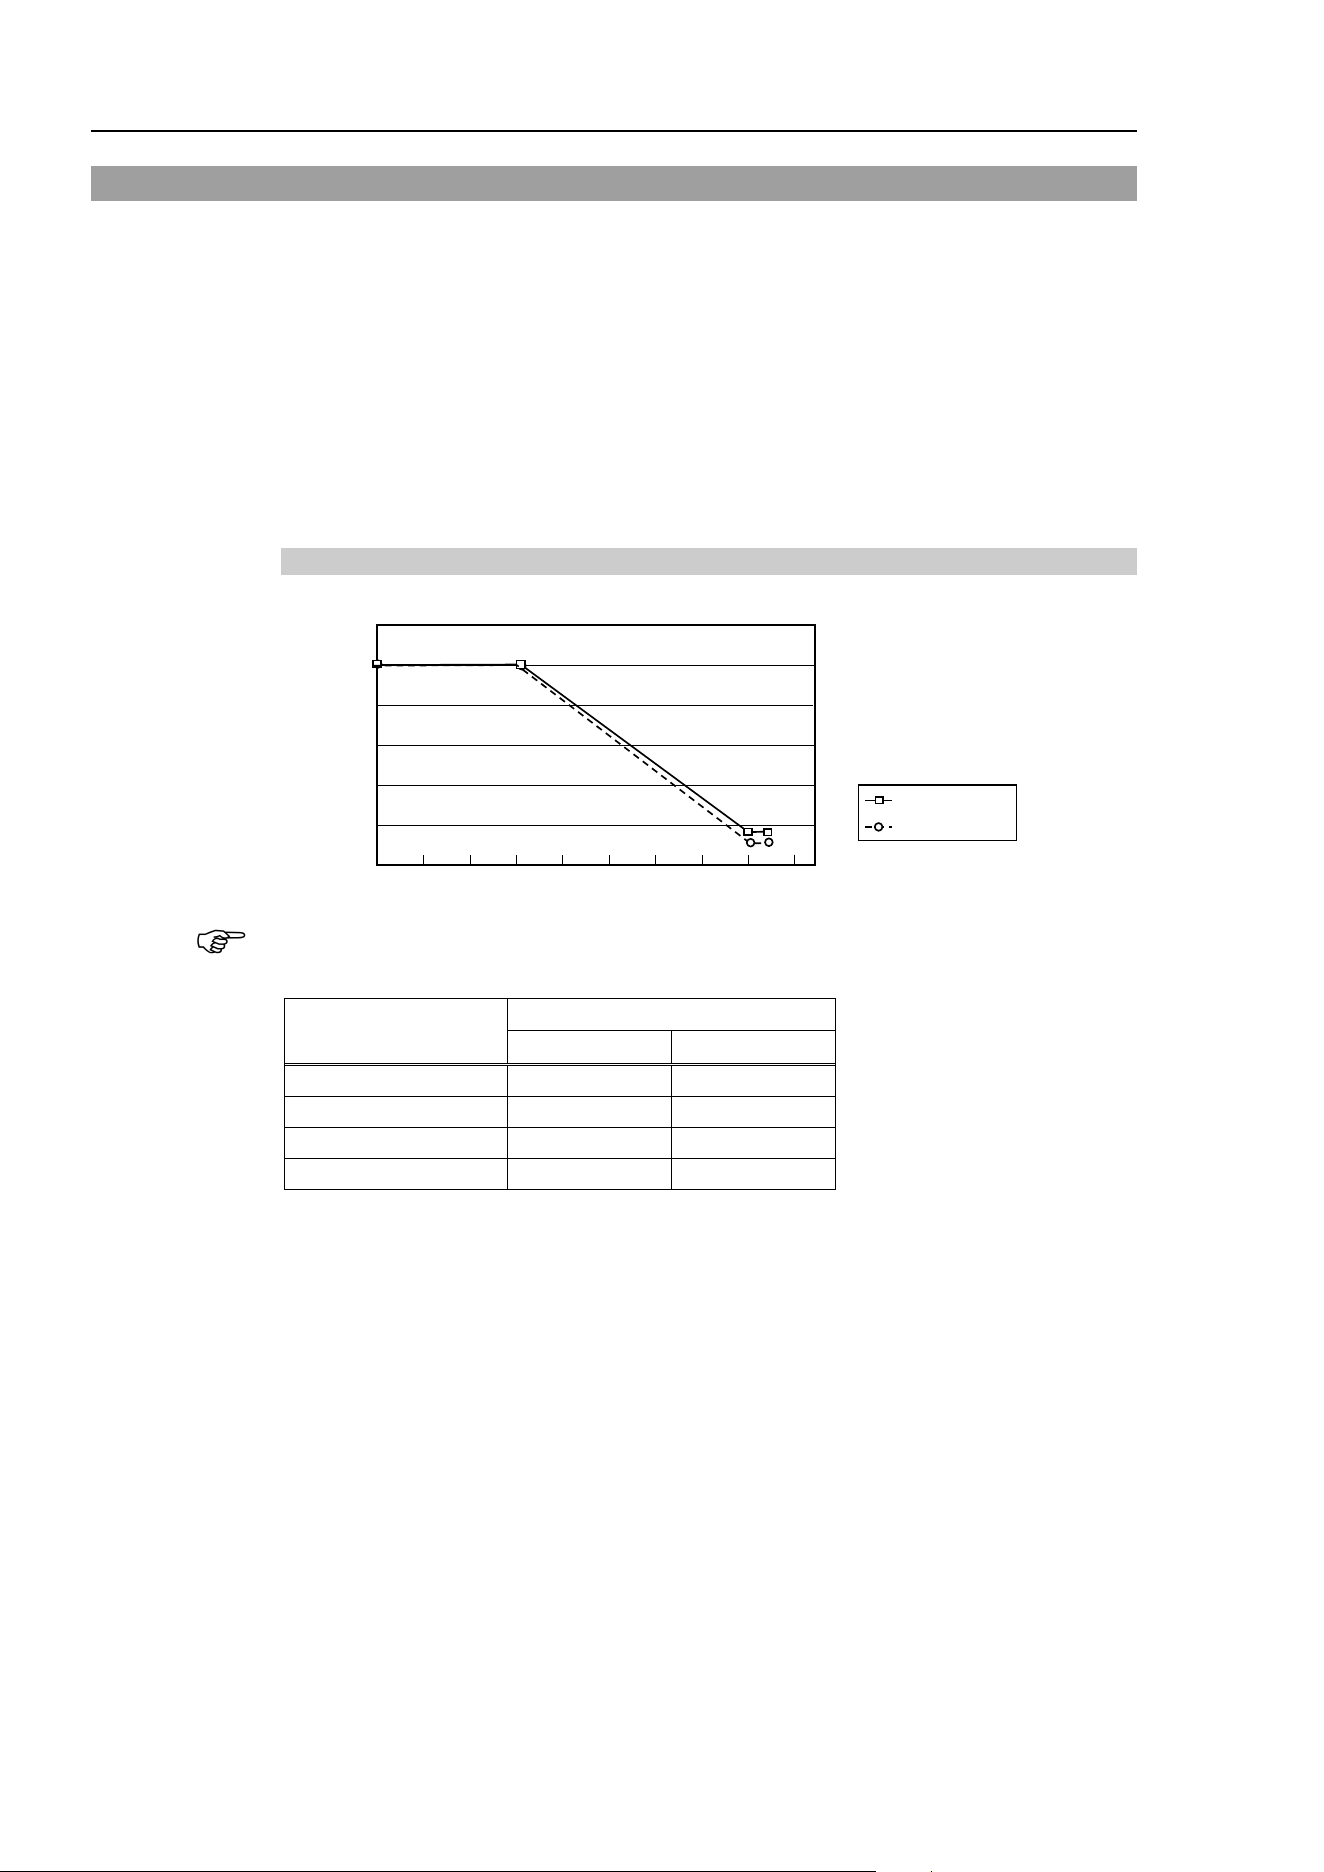
Setup & Operation 4. Setting of End Effectors
46
LS20-B Rev.4
4.4 Precautions for Auto Acceleration/Deceleration of Joint #3
When you move the Manipulator in horizontal PTP motion with Joint #3 (Z) at a high
position, the motion time will be faster.
When Joint #3 gets below a certain point, then auto acceleration/deceleration is used to
reduce acceleration/deceleration. (Refer to the figures below) The higher the position of
the shaft is, the faster the motion acceleration/deceleration is. However, it takes more time
to move Joint #3 up and down. Adjust the position of Joint #3 for the Manipulator motion
after considering the relation between the current position and the destination position.
The upper limit of Joint #3 during horizontal motion using Jump command can be set by the
LimZ command.
Automatic acceleration/deceleration vs. Joint #3 position
120
100
80
60
40
20
0 − 100 − 200 − 300 − 400 (mm) Shaft height
(%)
100
18
100
18
14
14
* Figures on the graph (%)
are the proportion to the
acceleration/deceleration
speed at the shaft upper
limit position.
LS20-BA04*
LS20
-B804*
When moving the Manipulator horizontally while the shaft is being lowered, it may cause
over-shoot at the time of final positioning.
Shaft height (mm)
Acceleration/Deceleration
LS20-B804*
LS20-BA04*
0
100
100
−150
100
100
−400
14
18
−42
0
14
18
NOTE
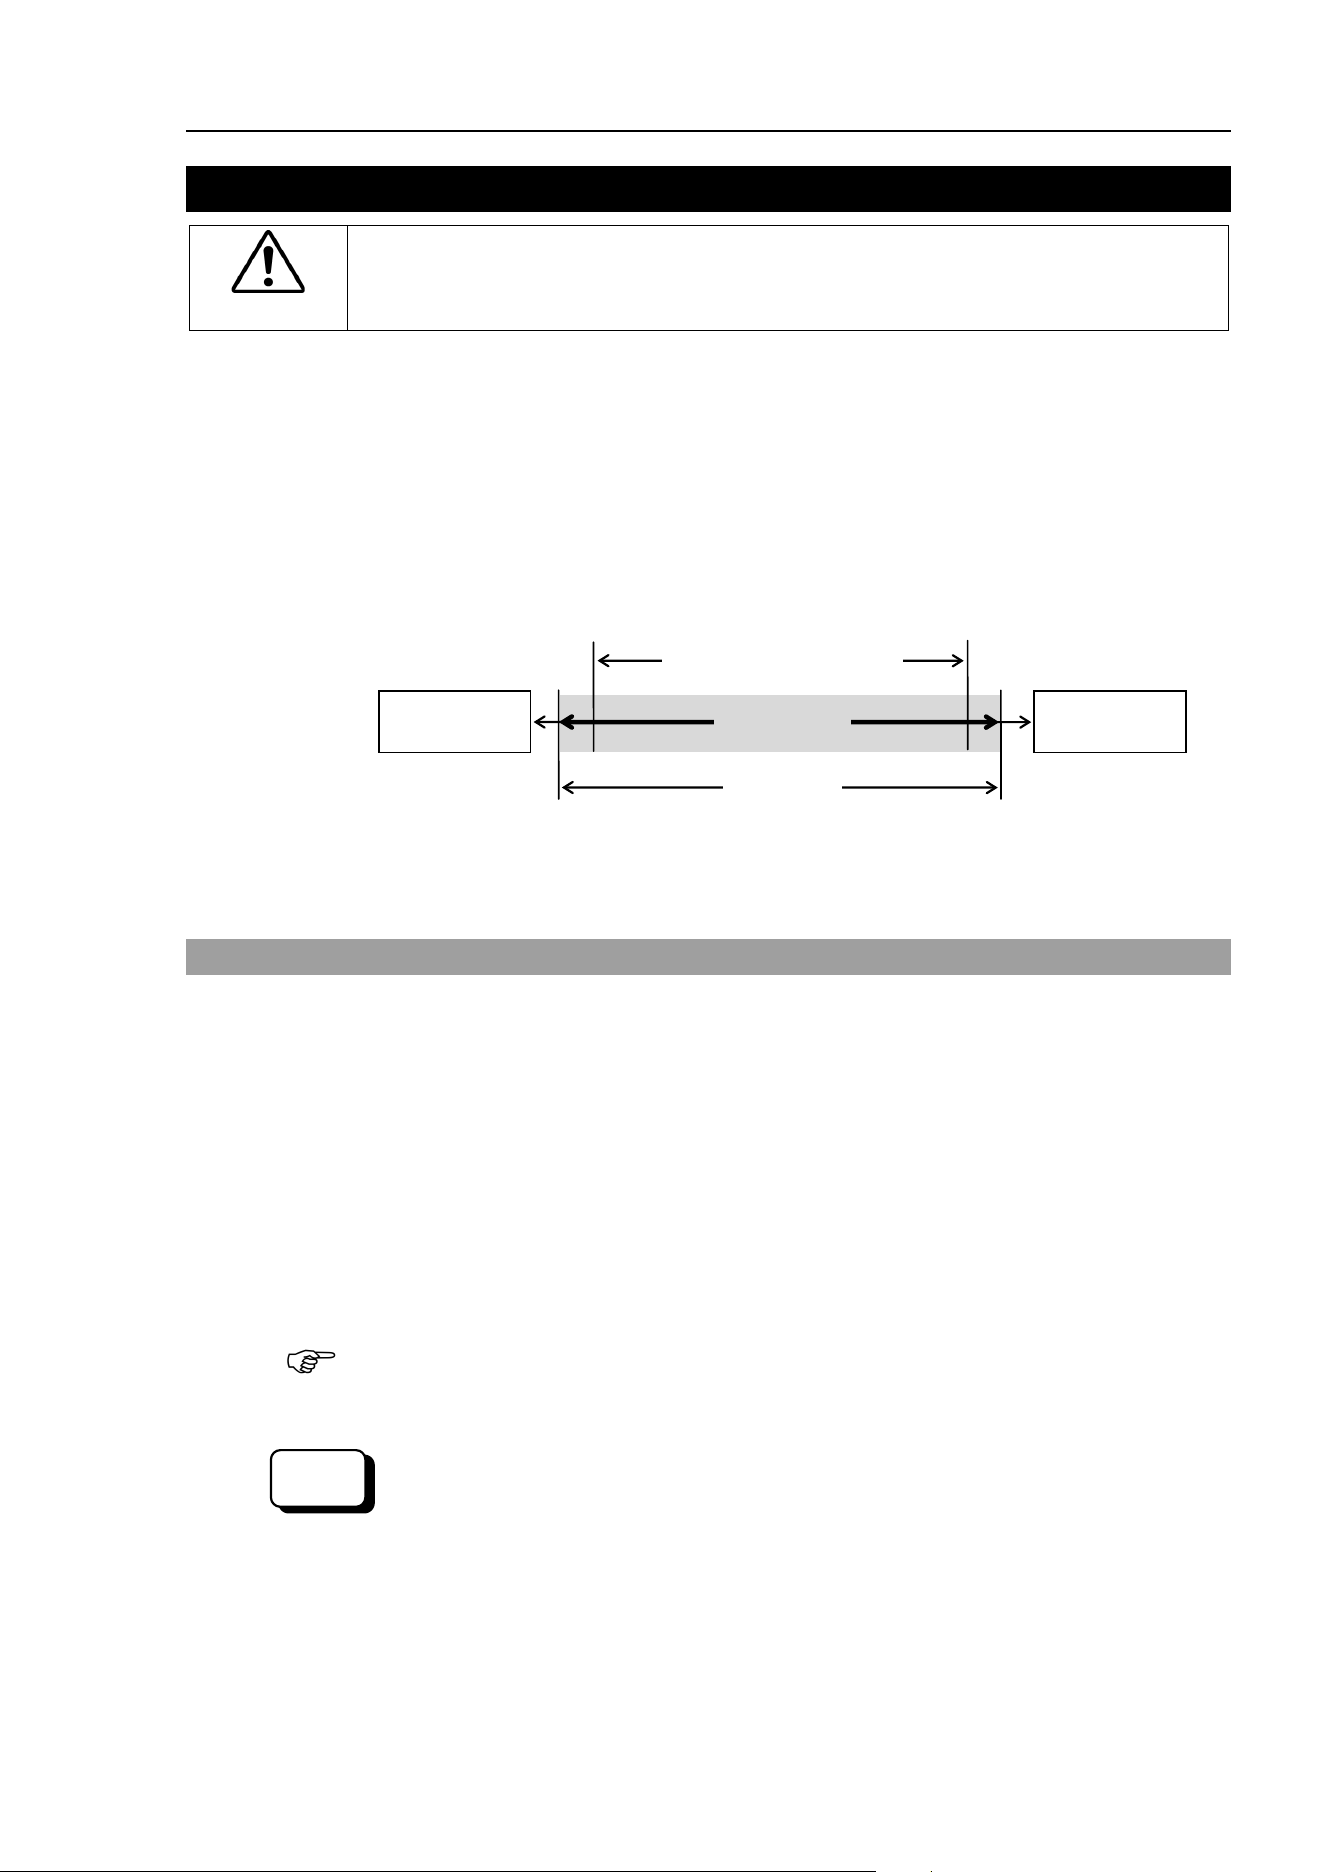
Setup & Operation 5. Motion Range
LS20-B Rev.4 47
5. Motion Range
CAUTION
■
When setting up the
motion range for safety, both the pulse range and
mechanical stops must always be set at the same time.
The motion range is preset at the factory as explained in Setup & Operation: 5.4 Standard
Motion Range. That is the maximum motion range of the Manipulator.
There are three methods for setting the motion range described as follows:
1. Setting by pulse range (for all joints)
2. Setting by mechanical stops (for Joints #1 to #3)
3. Setting the Cartesian (rectangular) range in the X, Y coordinate system of the
Manipulator (for Joints #1 and #2)
Mechanical
stop
Rectangular range setting
Pulse range
Motion range
Mechanical
stop
When the motion range is changed due to layout efficiency or safety, follow the descriptions
in 5.1 through 5.3 to set the range.
5.1 Motion Range Setting by Pulse Range
Pulses are the basic unit of Manipulator motion. The motion range of the Manipulator is
controlled by the pulse range between the pulse lower limit and upper limit of each joint.
Pulse values are read from the encoder output of the servo motor.
For the maximum pulse range, refer to the following sections.
The pulse range must be set inside of the mechanical stop range.
5.1.1 Max. Pulse Range of Joint #1
5.1.2 Max. Pulse Range of Joint #2
5.1.3 Max. Pulse Range of Joint #3
5.1.4 Max. Pulse Range of Joint #4.
Once the Manipulator receives an operating command, it checks whether the target position
specified by the command is within the pulse range before operating. If the target position
is out of the set pulse range, an error occurs and the Manipulator does not move.
The pulse range can be set on the [Range] panel shown by selecting [Tools]
-[Robot
Manager]. (You may also execute the Range command from the [Command Window].)
EPSON
RC+
NOTE
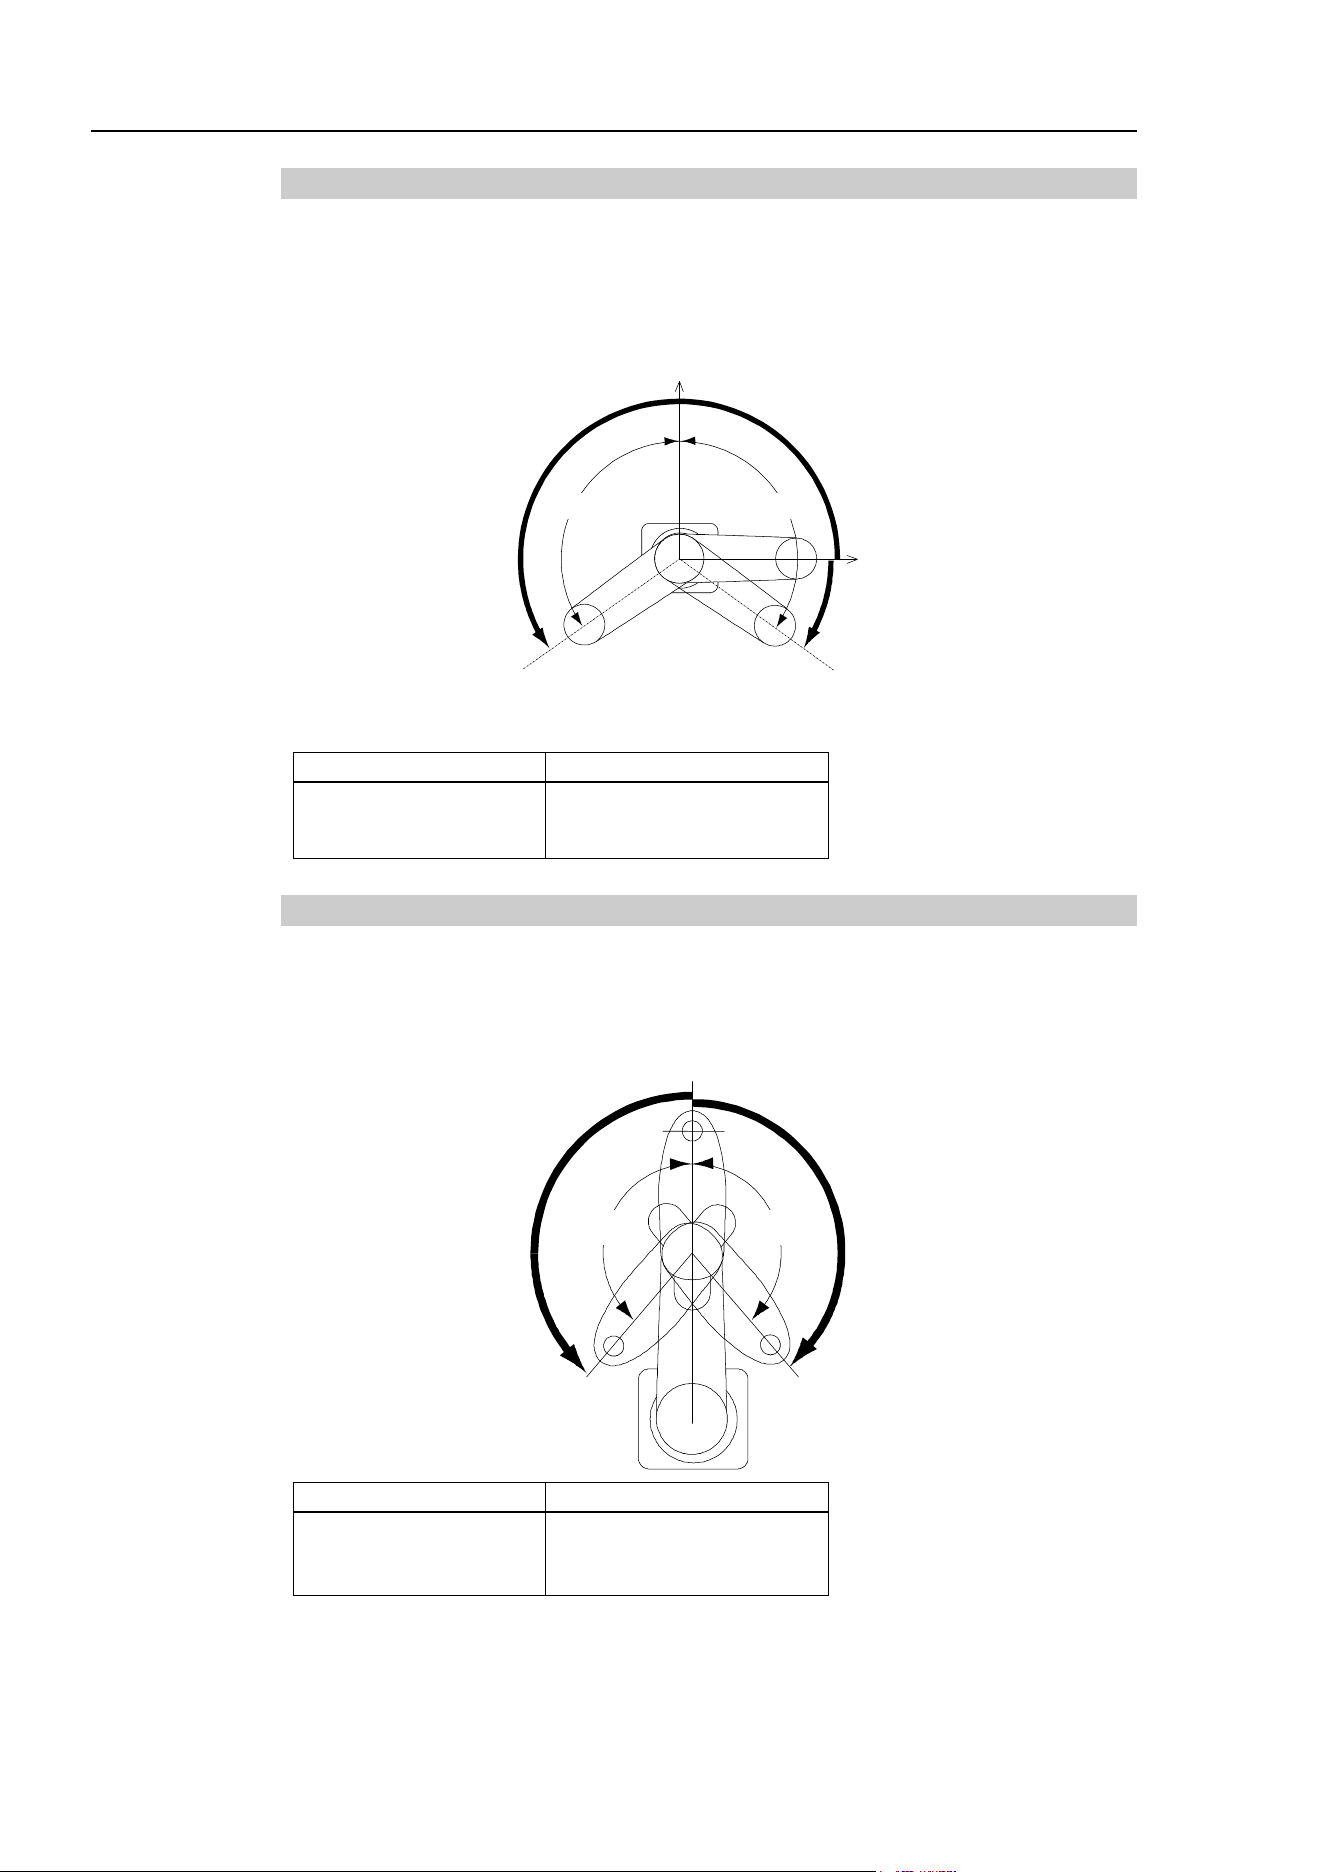
Setup & Operation 5. Motion Range
48
LS20-B Rev.4
5.1.1 Max. Pulse Range of Joint #1
The 0 (zero) pulse position of Joint #1 is the position where Arm #1 faces toward the positive
(+) direction on the X-coordinate axis.
When the 0 pulse is a starting point, the counterclockwise pulse value is defined as the
positive (+) and the clockwise pulse value is defined as the negative (-).
+Y
+X 0 pulse
+ B
− B
+ A
− A
A: Max. Motion Range
B: Max. Pulse Range
±132° − 152918 ~ 808278 pulse
5.1.2 Max. Pulse Range of Joint #2
The 0 (zero) pulse position of Joint #2 is the position where Arm #2 is in-line with Arm #1.
With the 0 pulse as a starting point, the counterclockwise pulse value is defined as the
positive (+) and the clockwise pulse value is defined as the negative (-).
− B
+ B
0 pulse
− A
+ A
A: Max. Motion Range
B: Max. Pulse Range
± 152°
± 345885 pulse
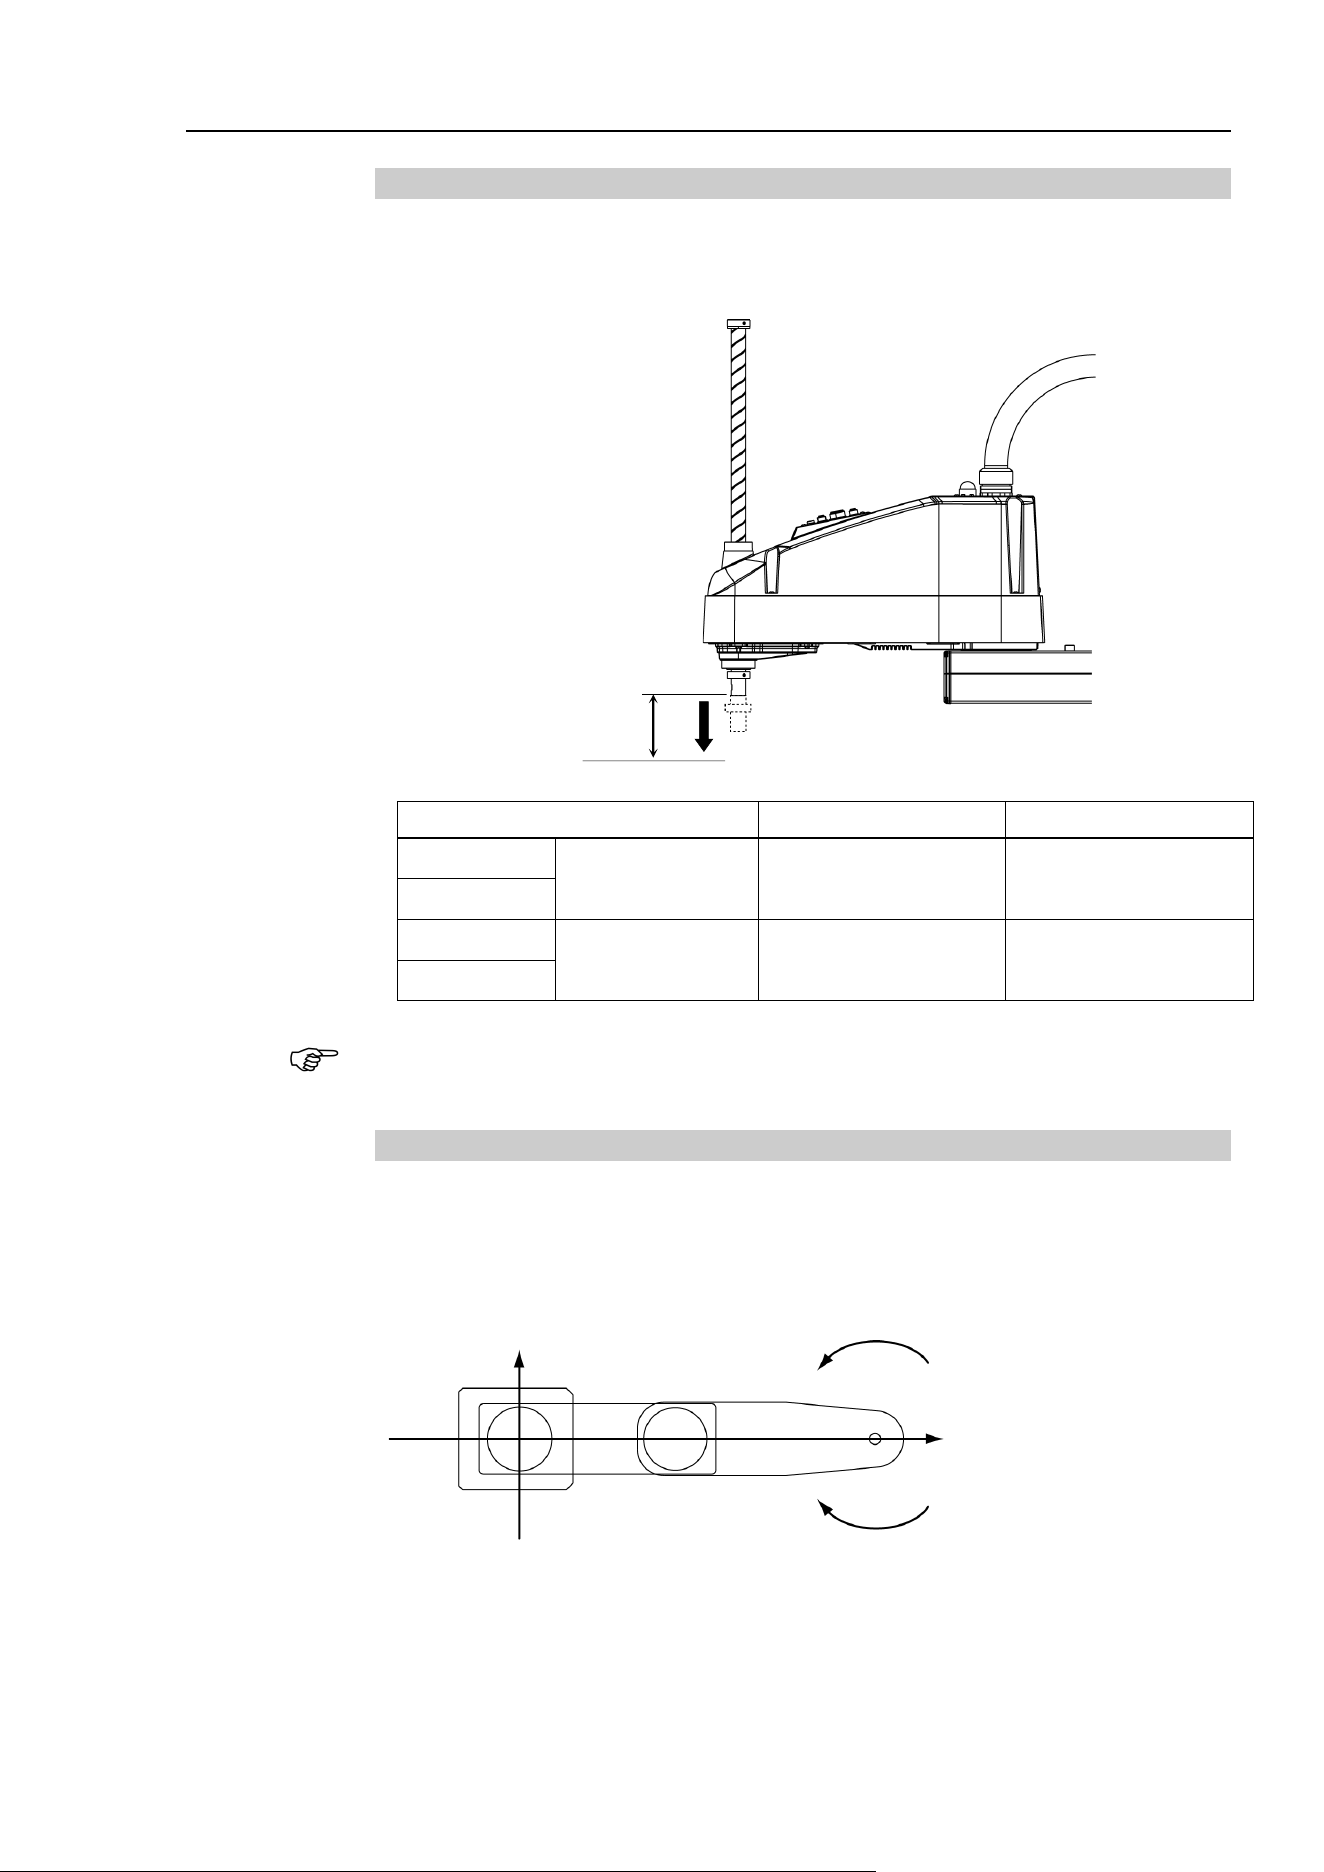
Setup & Operation 5. Motion Range
LS20-B Rev.4 49
5.1.3 Max. Pulse Range of Joint #3
The 0 (zero) pulse position of Joint #3 is the position where the shaft is at its upper limit.
The pulse value is always negative because Joint #3 always moves lower than the 0 pulse
position.
Upper limit: 0 pulse
Joint #3 Stroke Lower Limit Pulse
LS20-B804S
Standard-model 420 mm
−283853 pulse
LS20-BA04S
LS20-B804C
Cleanroom-model 390 mm
−263578 pulse
LS20-BA04C
For the Cleanroom-model, the motion range set with the Joint #3 mechanical stop cannot be
changed.
5.1.4 Max. Pulse Range of Joint #4
The 0 (zero) pulse position of Joint #4 is the position where the flat near the end of the shaft
faces toward the end of Arm #2. With the 0 pulse as a starting point, the counterclockwise
pulse value is defined as the positive (+) and the clockwise pulse value is defined as the
negative (-).
: +X 0 ± 344064 pulse
+Y
Clockwise (-value)
Counterclockwise (+value)
NOTE
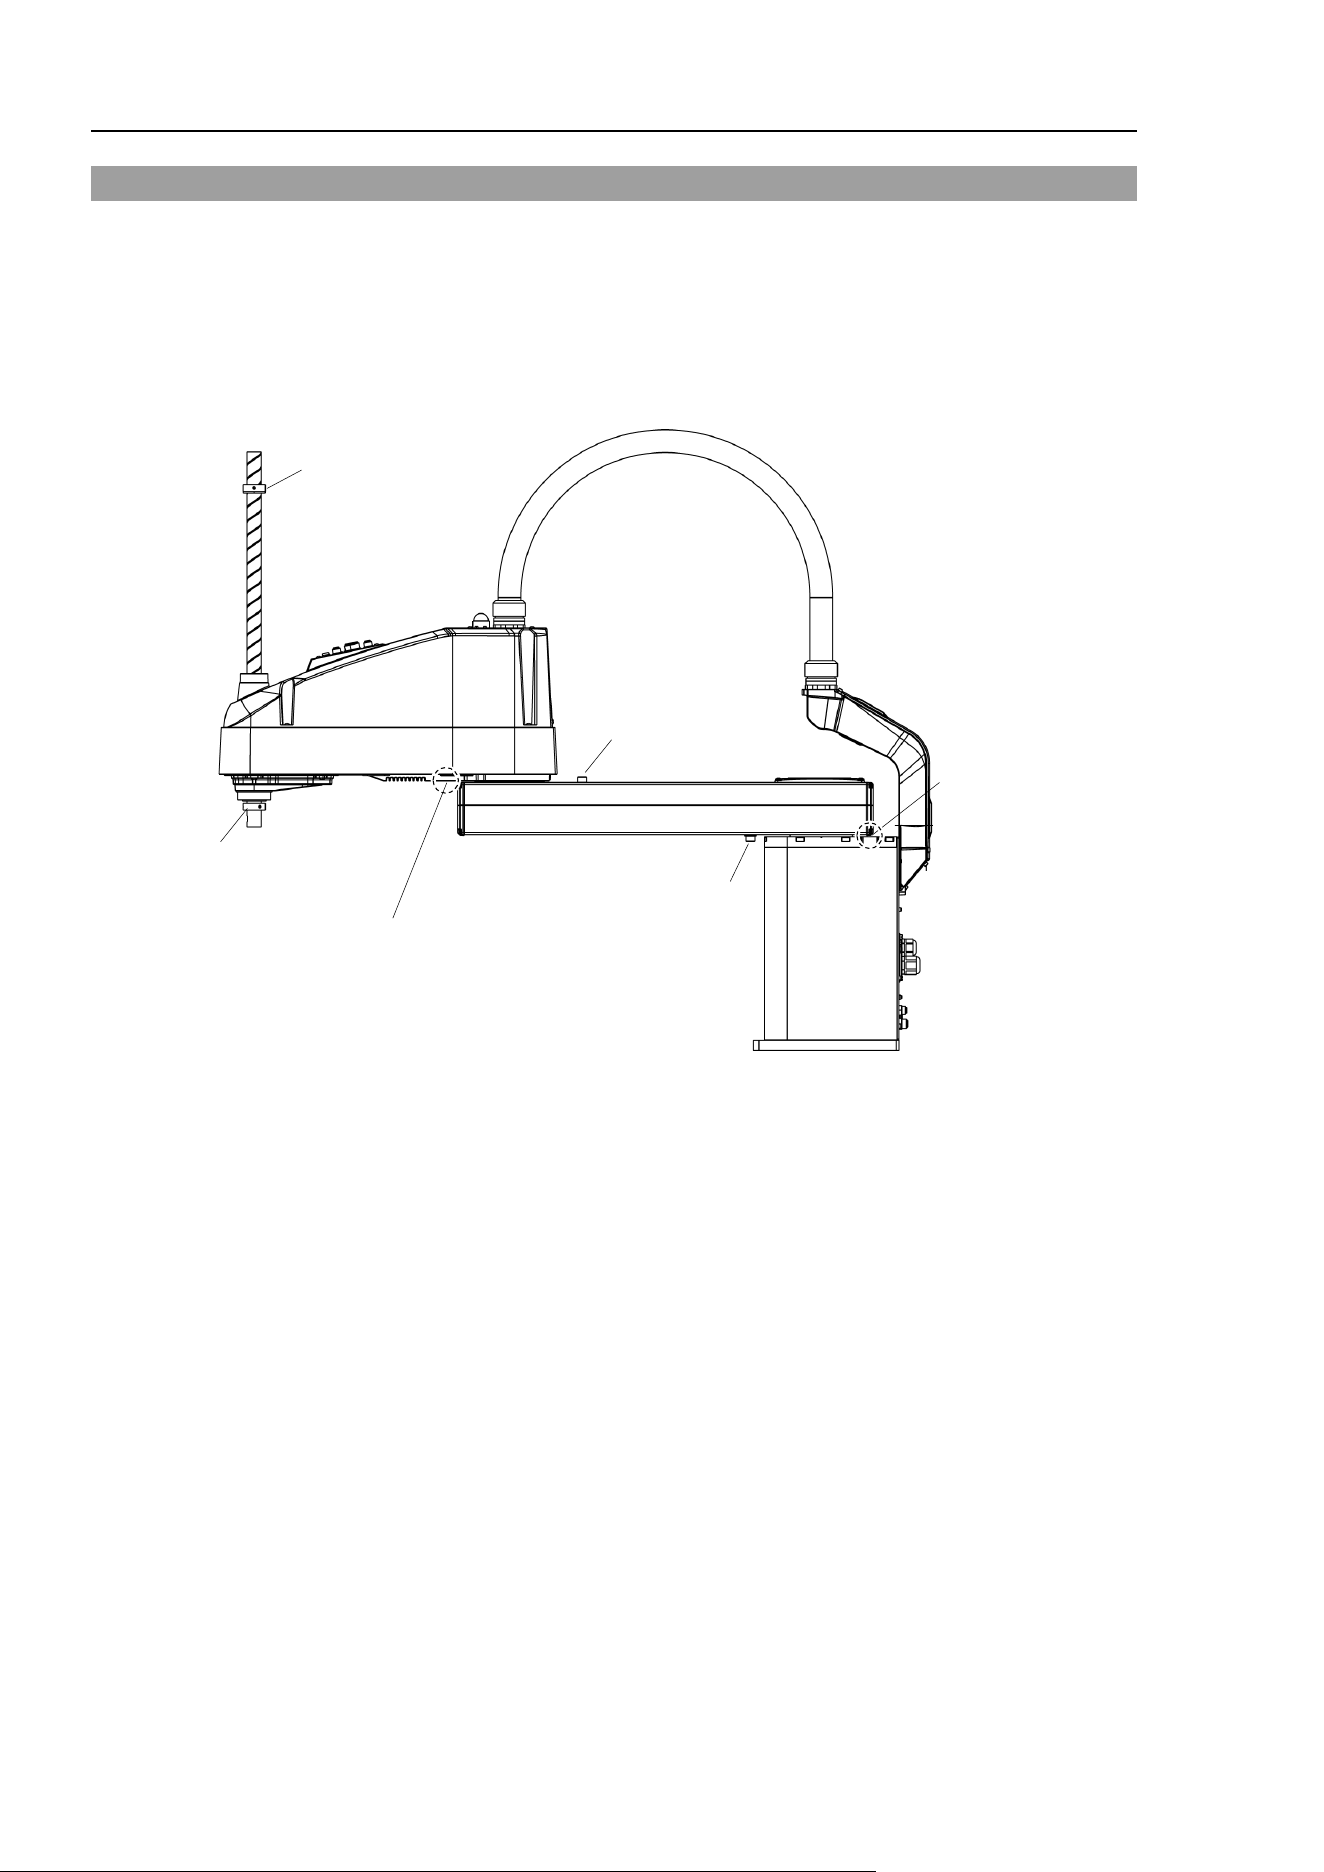
Setup & Operation 5. Motion Range
50
LS20-B Rev.4
5.2 Motion Range Setting by Mechanical Stops
Mechanical stops physically limit the absolute area that the Manipulator can move.
Both Joints #1 and #2 have threaded holes in the positions corresponding to the angle for
the mechanical stop settings. Install the bolts in the holes corresponding to the angle that
you want to set.
Joints #3 can be set to any length less than the maximum stroke.
(Mechanical stop of Joint #2)
Mechanical stop of Joint #1
(Adjustable)
Mechanical stop of Joint #3
(Lower limit mechanical stop)
(Do not move the position of
upper limit mechanical stop.)
(Mechanical stop of
Joint #1)
Mechanical stop of
Joint #2 (Adjustable)
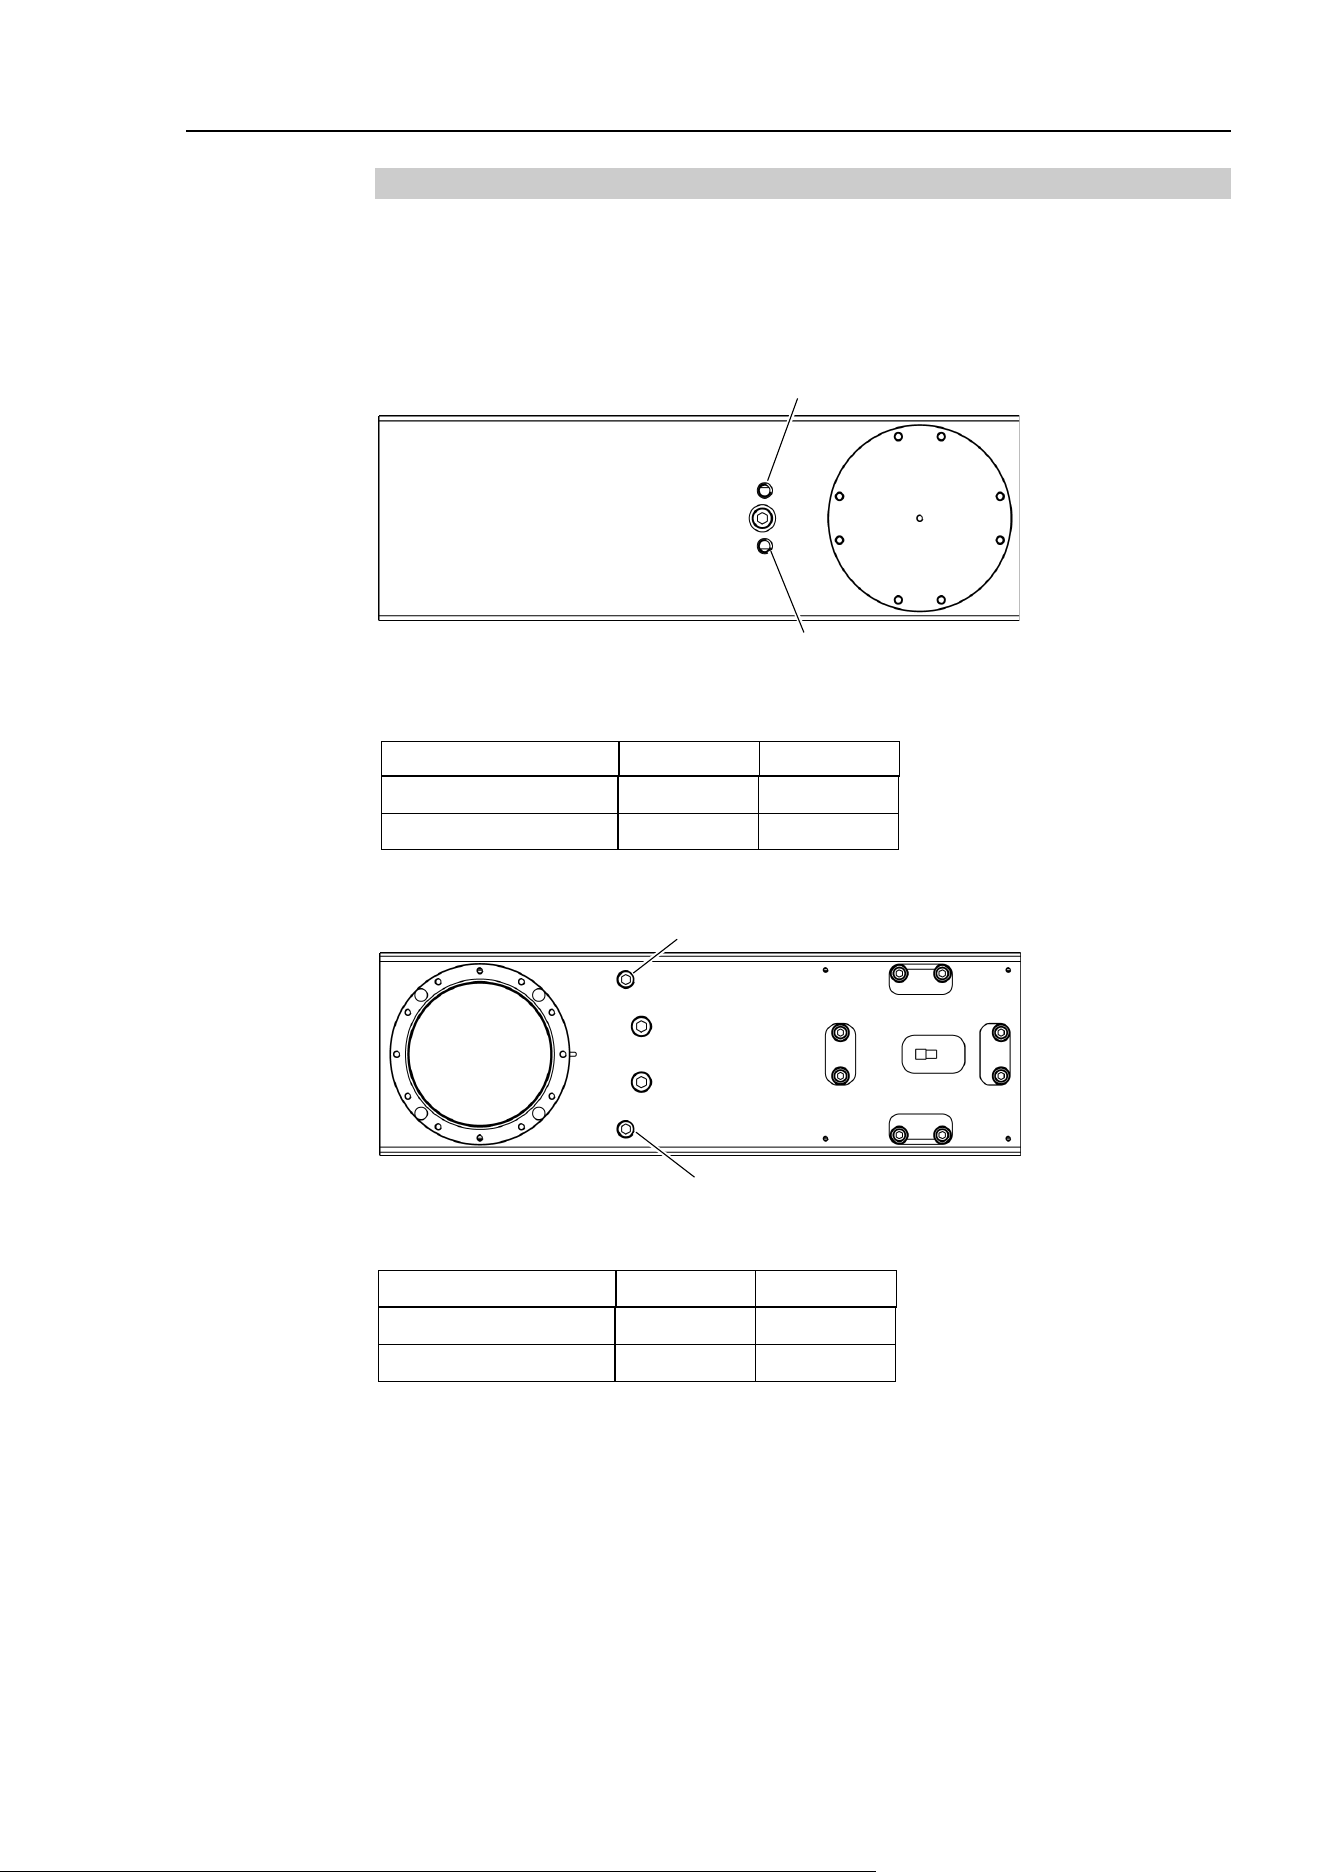
Setup & Operation 5. Motion Range
LS20-B Rev.4 51
5.2.1 Setting the Mechanical Stops of Joints #1 and #2
Both Joints #1 and #2 have threaded holes in the positions corresponding to the angle for
the mechanical stop settings. Install the bolts in the holes corresponding to the angle that
you want to set.
Install the bolts for the mechanical stop to the following position.
Views from the bottom of Arm #1
Joint #1 Mechanical Stops
a
b
a
b
Setting Angle (
°
)
122
−122
Pulse Value (pulse)
771868
−
116508
Views from the top of Arm #1
Joint #2 Mechanical Stops
a
b
a
b
Setting Angle (
°
)
135
−
135
Pulse Value (pulse)
307200
−
307200
Setup & Operation 5. Motion Range
52
LS20-B Rev.4
(1)
Turn OFF the
Controller.
(2)
Install
a hexagon socket head cap bolt into the hole corresponding to the setting angle,
and
tighten it.
Joint
Hexagon socket head cap
bolt (fully threaded)
The number
of bolts
Recommended
tightening torque
1
M8 × 10
1 bolt / side
13.0 N⋅m (132.7 kgf⋅cm)
2
M10 × 50
(3)
Turn ON the
Controller.
(4)
Set the pulse range corresponding to the new positions of the mechanical stops.
Be sure to set the pulse range
inside the positions of the mechanical stop range.
Example:
Using LS20-B804S
The angle of Joint #1 is set from −110 to +110°.
The angle of Joint #2 is set from −120 to +120°.
Execute the following command
s from the [Command Window].
>JRANGE 1, -72817, 728177 ' Sets the pulse range of Joint #1
>JRANGE 2, -273066, 273066 ' Sets the pulse range of Joint #2
>RANGE ' Checks the setting using Range
-72817, 728177, -273066, 273066, -283853, 0,
-344064, 344064
(5)
Move the arm by hand until it touches the mechanical stops
, and make sure that the
arm
does not hit
any peripheral equipment during operation.
(6)
O
perate the joint changed at low speeds until it reaches the positions of the
minimum
and
maximum pulse range.
Make sure that the arm does not hit the mechanical stops.
(Check the
position of the mechanical stop and the motion range you set.)
Example
: Using LS20-B804S
The angle of Joint #1 is set from −110 to +110°.
The angle of Joint #2 is set from −120 to +120°.
Execute the following command
s from the [Command Window].
>MOTOR ON ' Turns ON the motor
>POWER LOW ' Enters low-power mode
>SPEED 5 ' Sets at low speeds
>PULSE -72817,0,0,0 ' Moves to the min. pulse position of Joint #1
>PULSE 728177,0,0,0 ' Moves to the max. pulse position of Joint #1
>PULSE 327680,-273066,0,0 ' Moves to the min. pulse position of Joint #2
>PULSE 327680,273066,0,0 ' Moves to the max. pulse position of Joint #2
The Pulse command (Go Pulse command) moves
all joints to the specified positions
at
the same time.
Specify safe positions after considering motion of not only the joints
whose pulse range have been changed, but also other joints
.
In this example, Joint #1 is moved to
0° position where is close to the
center of its
mot
ion range (pulse value: 327680) when checking Joint #2.
If the arm
is hitting the mechanical stop
s or if an error occurs after the arm hits the
mechanical stops
, either
reset the pulse range to a narrower setting or extend the
position
s of the mechanical stops within the limit.
EPSON
RC+
EPSON
RC+
NOTE
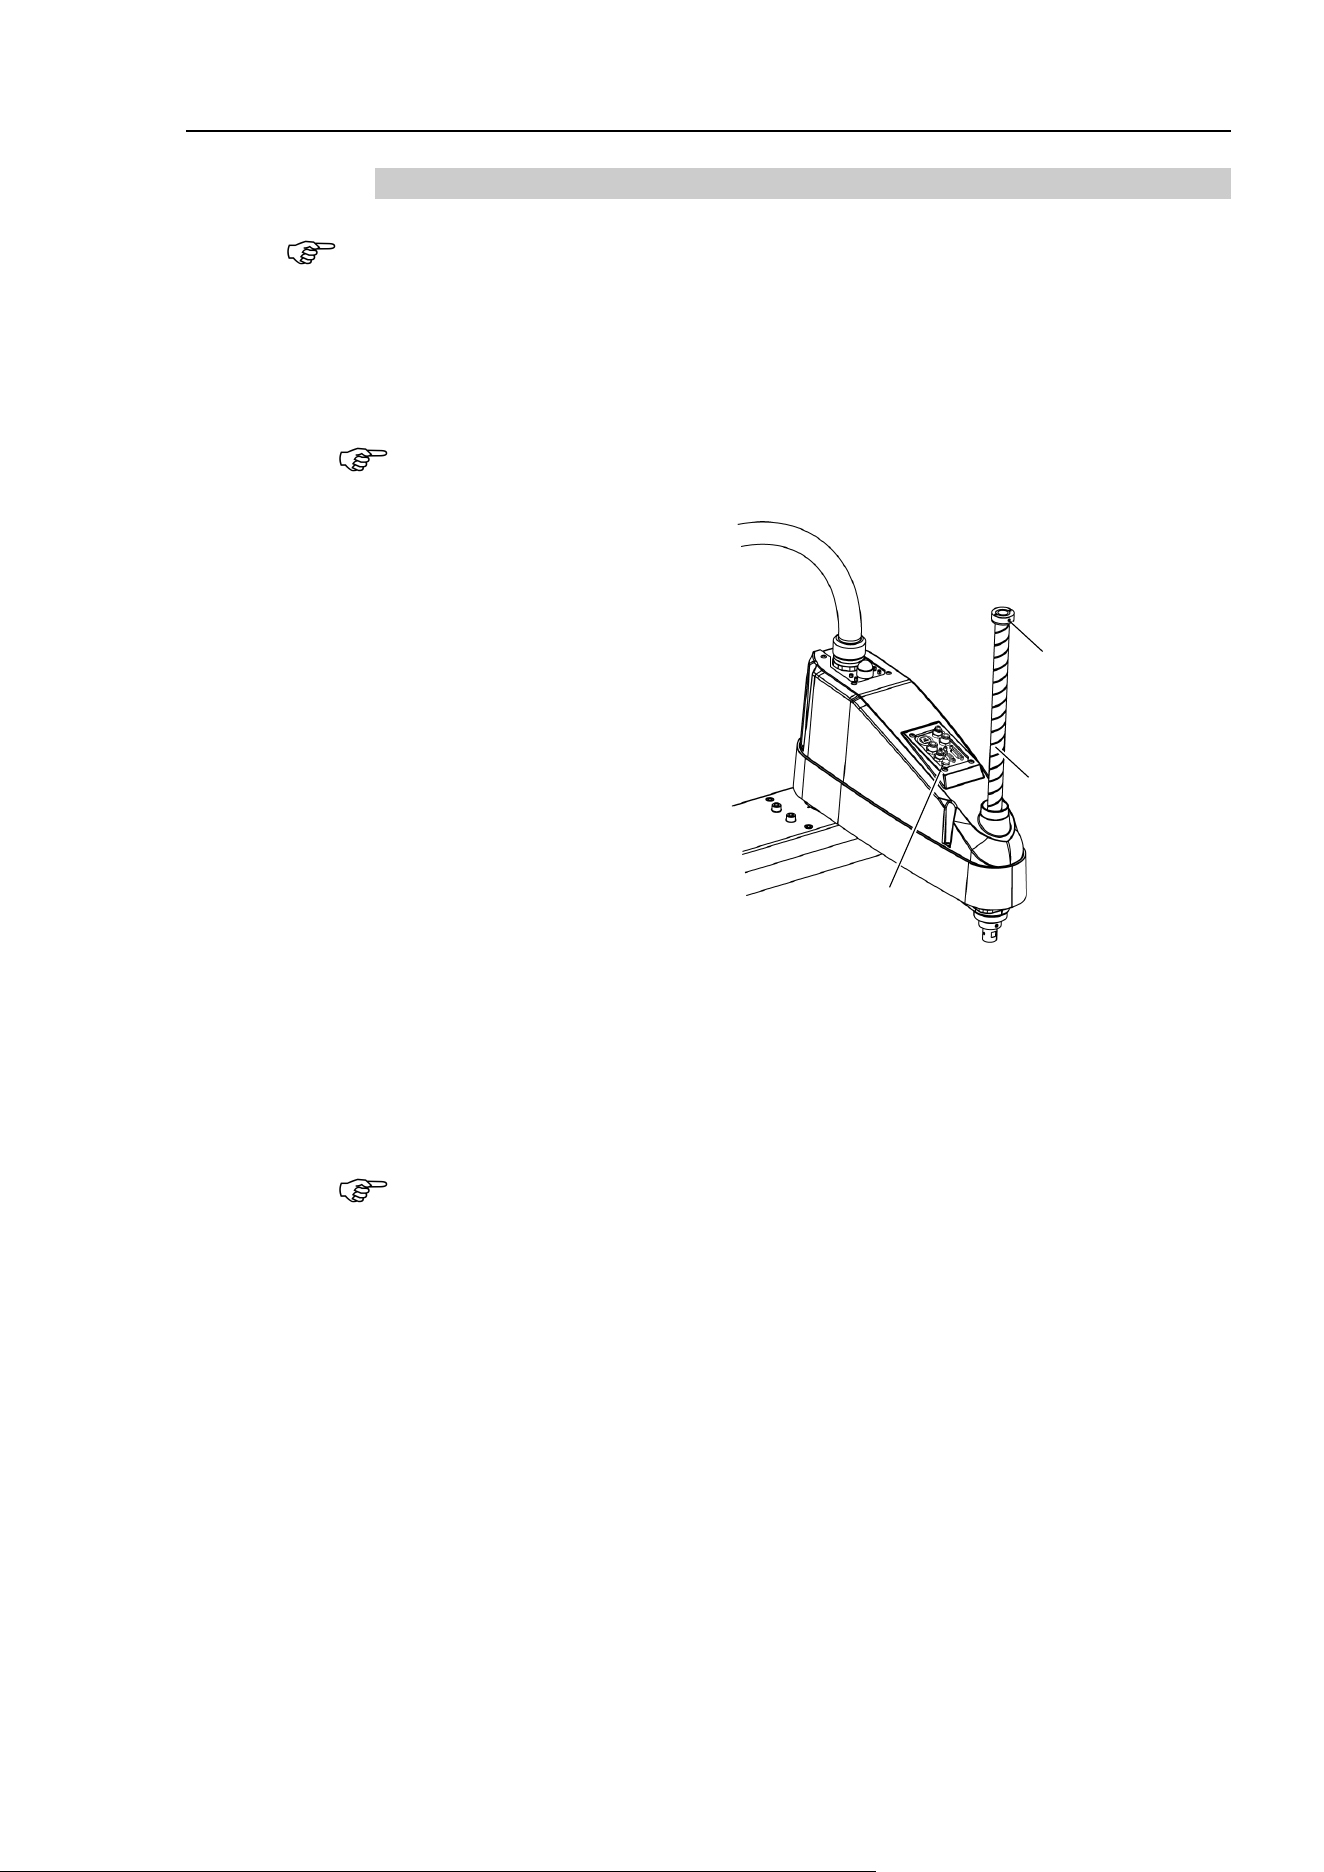
Setup & Operation 5. Motion Range
L
S20-B Rev.4 53
5.2.2 Setting the Mechanical Stop of Joint #3
This method applies only to the Standard-model (LS20-B**4S) manipulator.
For the Cleanroom-model (LS20-B**4C), the motion range set with the Joint #3 mechanical
stop cannot be changed.
(1)
Turn ON the Controller and turn OFF the motors using the Motor OFF command.
(2)
Push up the shaft while pressing the brake release switch.
Do not push the shaft up to its upper limit or it will be
difficult for the arm top cover to
be removed. Push the shaft up to a position where the Joint #3 mechanical stop can
be changed.
Lower limit mechanical
stop screw
Set screw: 2-M5×6
+2-M5 Bushing
Brake Release Switch
Shaft
When you press
the brake release switch, the shaft may lower or rotate due to the
weight o
f the end effector. Be sure to hold the shaft by hand while pressing the button.
(3)
Turn OFF the
Controller.
(4)
Loosen the lower limit mechanical stop screw
(set screws: 2-M5×6).
A mechanical stop is
mounted on both the top and bottom of Joint #3. However, only
the position of the lower limit mechanical stop on
the top can be changed.
Do not remove the upper limit mechanical stop on the bottom because the calibration
point of Joint #3 is specified
using the stop.
NOTE
NOTE
NOTE
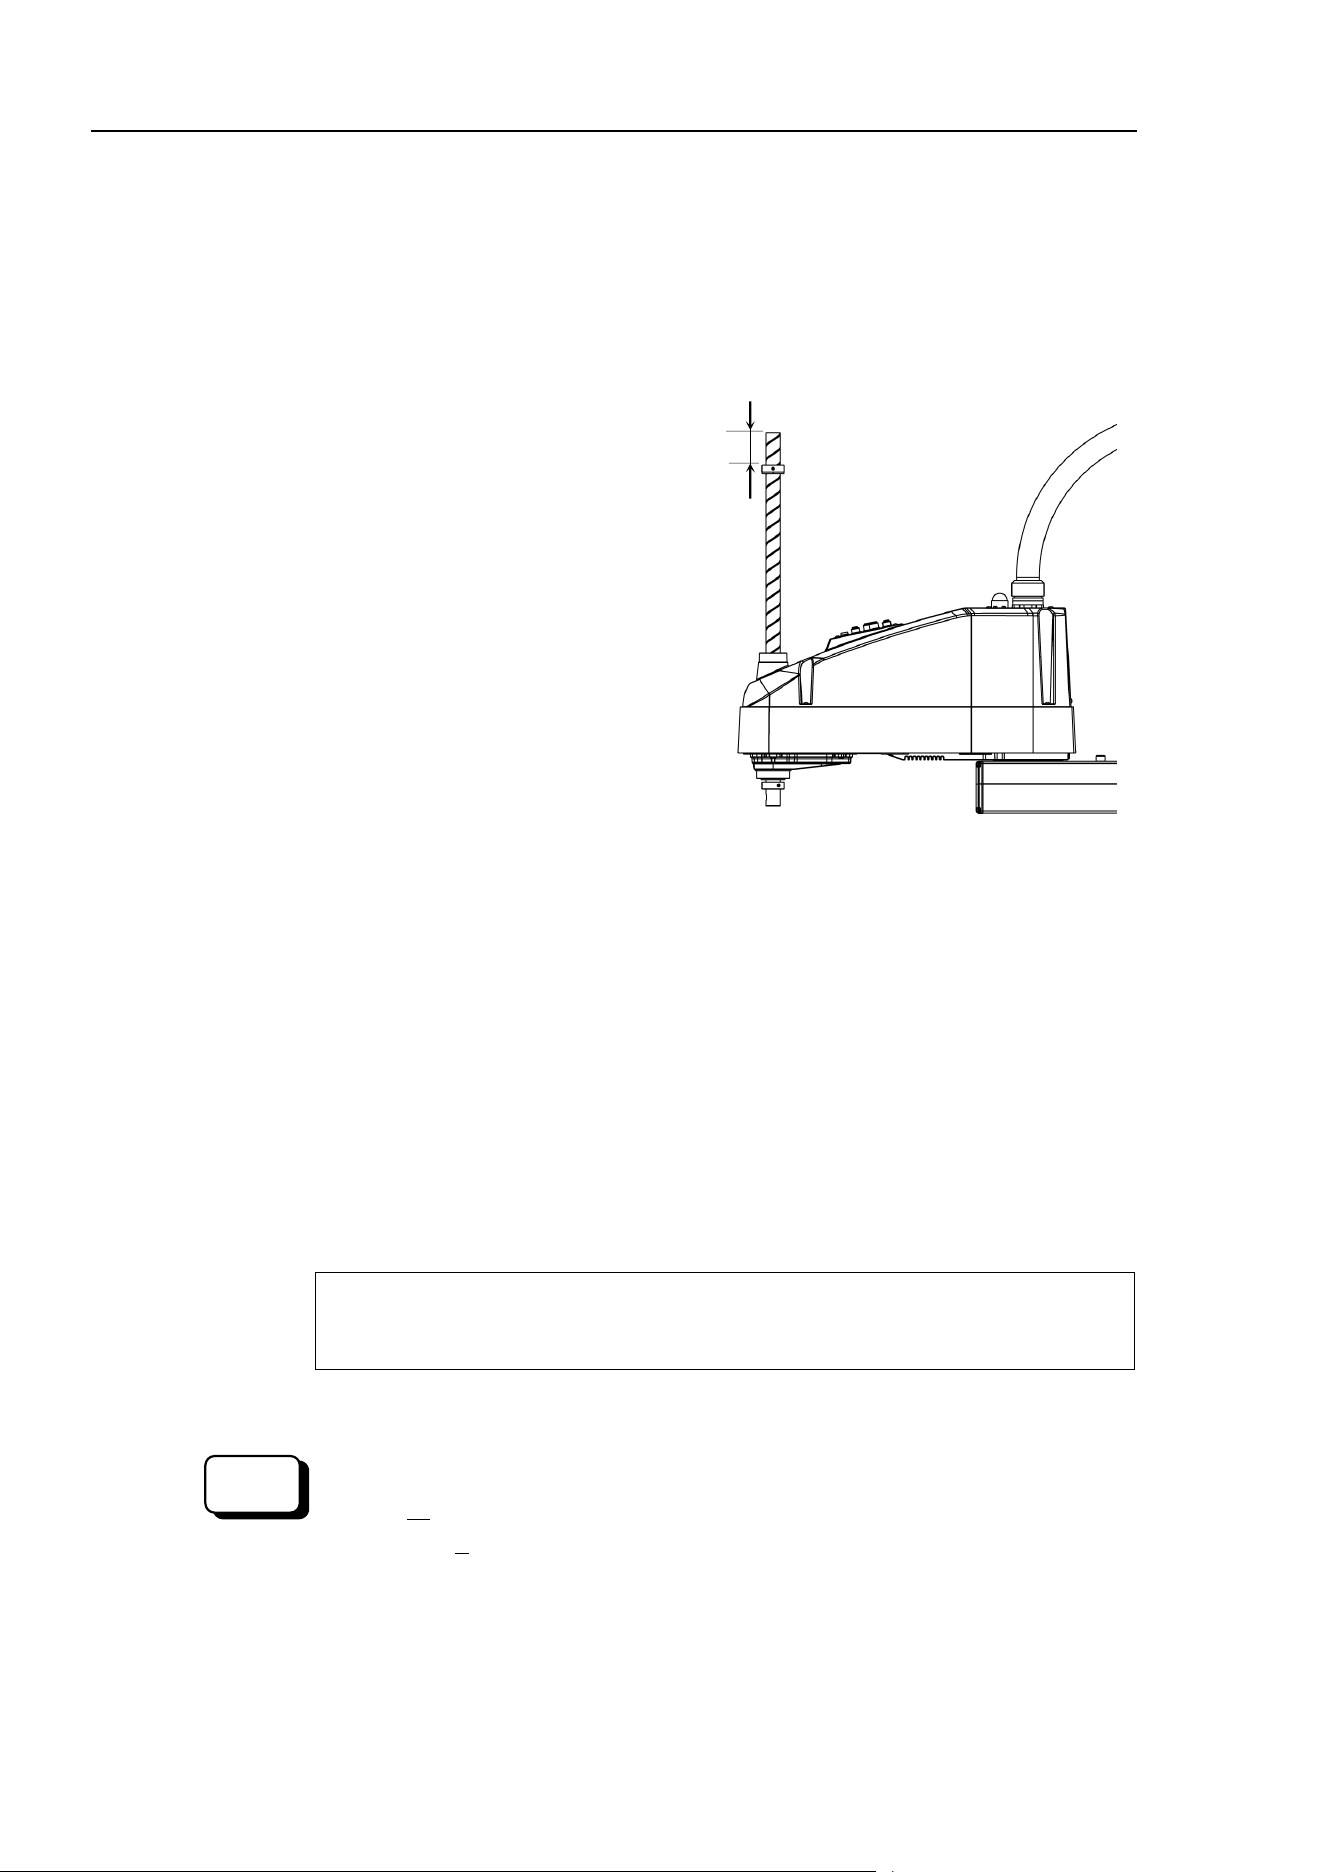
Setup & Operation 5. Motion Range
54 L
S20-B Rev.4
(5)
The upper end of the shaft
defines the maximum stroke. Move the lower limit
mechanical stop down by the length you want to limit the stroke.
For example, when the lower limit mechanical stop is set at
“420 mm” stroke, the
lower
limit Z coordinate value is “−420”. To change the value to “−100”, move the
lower limit mechanical stop down
“320 mm”. Use calipers to measure the distance
when
adjusting the mechanical stop.
Measure this
distance
(6)
Firmly tighten the lower limit mechanical stop screw
(set screws: 2-M5×6).
Recommended tightening torque:
3.9 N·m (39.8 kgf·cm)
(7)
Turn ON the
Controller.
(8)
Move
Joint #3 to its lower limit while pressing the brake release switch, and
then check
the lower
limit position. Do not lower the mechanical stop too far
. Otherwise, the
joint
may not reach a target position.
(9)
Calculate the lower limit pulse
value of the pulse range using the formula
shown below
and set the value.
T
he result of the calculation is always negative because t
he lower limit Z coordinate
value
is negative.
Lower limit of pulse (p
ulse)
= lower limit Z coordinate value (mm) / Resolution (
mm/pulse)
** For the Joint #3 resolution,
refer to the section Setup & Operation 2.4 Specifications.
Execute the following command from the [Command Window].
Enter the calculated
value in X.
>JRANGE 3,X,0 ' Sets the pulse range of Joint #3
(10)
Using the
Pulse command (Go Pulse command), move
Joint #3 to the lower limit
position of the pulse range at low speed.
If the mechanical stop range is less
than the
pulse range, Joint #3
will hit the mechanical stop and an error will occur.
When the
error occurs, either change
the pulse range to a lower setting
or extend the position of the
mechanical stop within the limit.
EPSON
RC+
Setup & Operation 5. Motion Range
L
S20-B Rev.4 55
If it is difficult to check whether Joint #3 hits a mechanical stop, turn OFF the Controller
and lift the arm top cover to check the condition causing the problem from the side.
Execute the following commands from the [Command Window].
Enter the value
calculated in Step (9) in X.
>MOTOR ON
' Turns ON the motor
>SPEED 5
' Sets low speed
>PULSE 0,0,
X,0 ' Moves to the lower limit-pulse position of Joint #3.
(In this example, all pulses except those for Joint #3 are “0”. S
ubstitute
these “0s” with the other pulse values specifying a position where there
is
no interference even when lowering Joint #3.)
5.3 Setting the Cartesian (Rectangular) Range in the XY
Coordinate System of the Manipulator (for Joints #1 and #2)
Use this method to set the upper and lower limits of the X and Y coordinates.
This setting is only enforced by software. Therefore, it does not change the physical range.
The maximum physical range is based on the position of the mechanical stops.
Set the XYLim setting on the [XYZ Limits] panel
shown by selecting [Tools]-
[Robot
Manager].
(You may also execute the XYLim command from the [Command Window].)
EPSON
RC+
EPSON
RC+
NOTE
Setup & Operation 5. Motion Range
56
LS20-B Rev.4
5.4 Standard Motion Range
The following “motion range” diagrams show the standard (maximum) specification.
When each Joint motor is under servo control, the center of Joint #3’s (shaft’s) lowest point
moves in the areas shown in the figure.
“Area limited by mechanical stop” is the area where the center of Joint #3’s lowest point
can be moved when each joint motor is not under servo control.
“Mechanical stop” sets the limited motion range so that the center of Joint #3 cannot move
beyond the area mechanically.
“Maximum space” is the area that contains the farthest reach of the arms. If the maximum
radius of the end effector is over 60 mm, add the “Area limited by mechanical stop” and
“radius of the end effector”. The total value is specified as the maximum area.
A
Center of Joint #3
B
Motion range
C
Maximum range
D
Base mounting face
E
Area limited by a mechanical stop
LS20-B804*
LS20-BA04*
a
Arm #1 + Arm #2 length [mm]
800
1000
b
Arm #1 length [mm]
350
550
c
Arm #2 length [mm]
450
d
Joint #1 motion angle [°]
132
e
Joint #2 motion angle [°]
152
f
(Motion range)
216.5
260.7
g
(Motion range at the rear)
684.2
818
h
Angle of the Joint #1 mechanical stop [°]
2.0
i
Angle of the Joint #2 mechanical stop [°]
3.6
j
(Mechanical stop area)
195.3
232.8
k
(Mechanical stop area at the rear)
693.1
832.1
m (Joint #3 motion range)
LS20-B***S
420
LS20-B***C
390
n (Distance from the base mounting face)
LS20-B***S
26.5
LS20-B***C
33.7
p (Joint #3 mechanical stop area upper end)
LS20-B***S
4
LS20-B***C
3.2
q (Joint #3 mechanical stop area lower end)
LS20-B***S
3
LS20-B***C
1.8
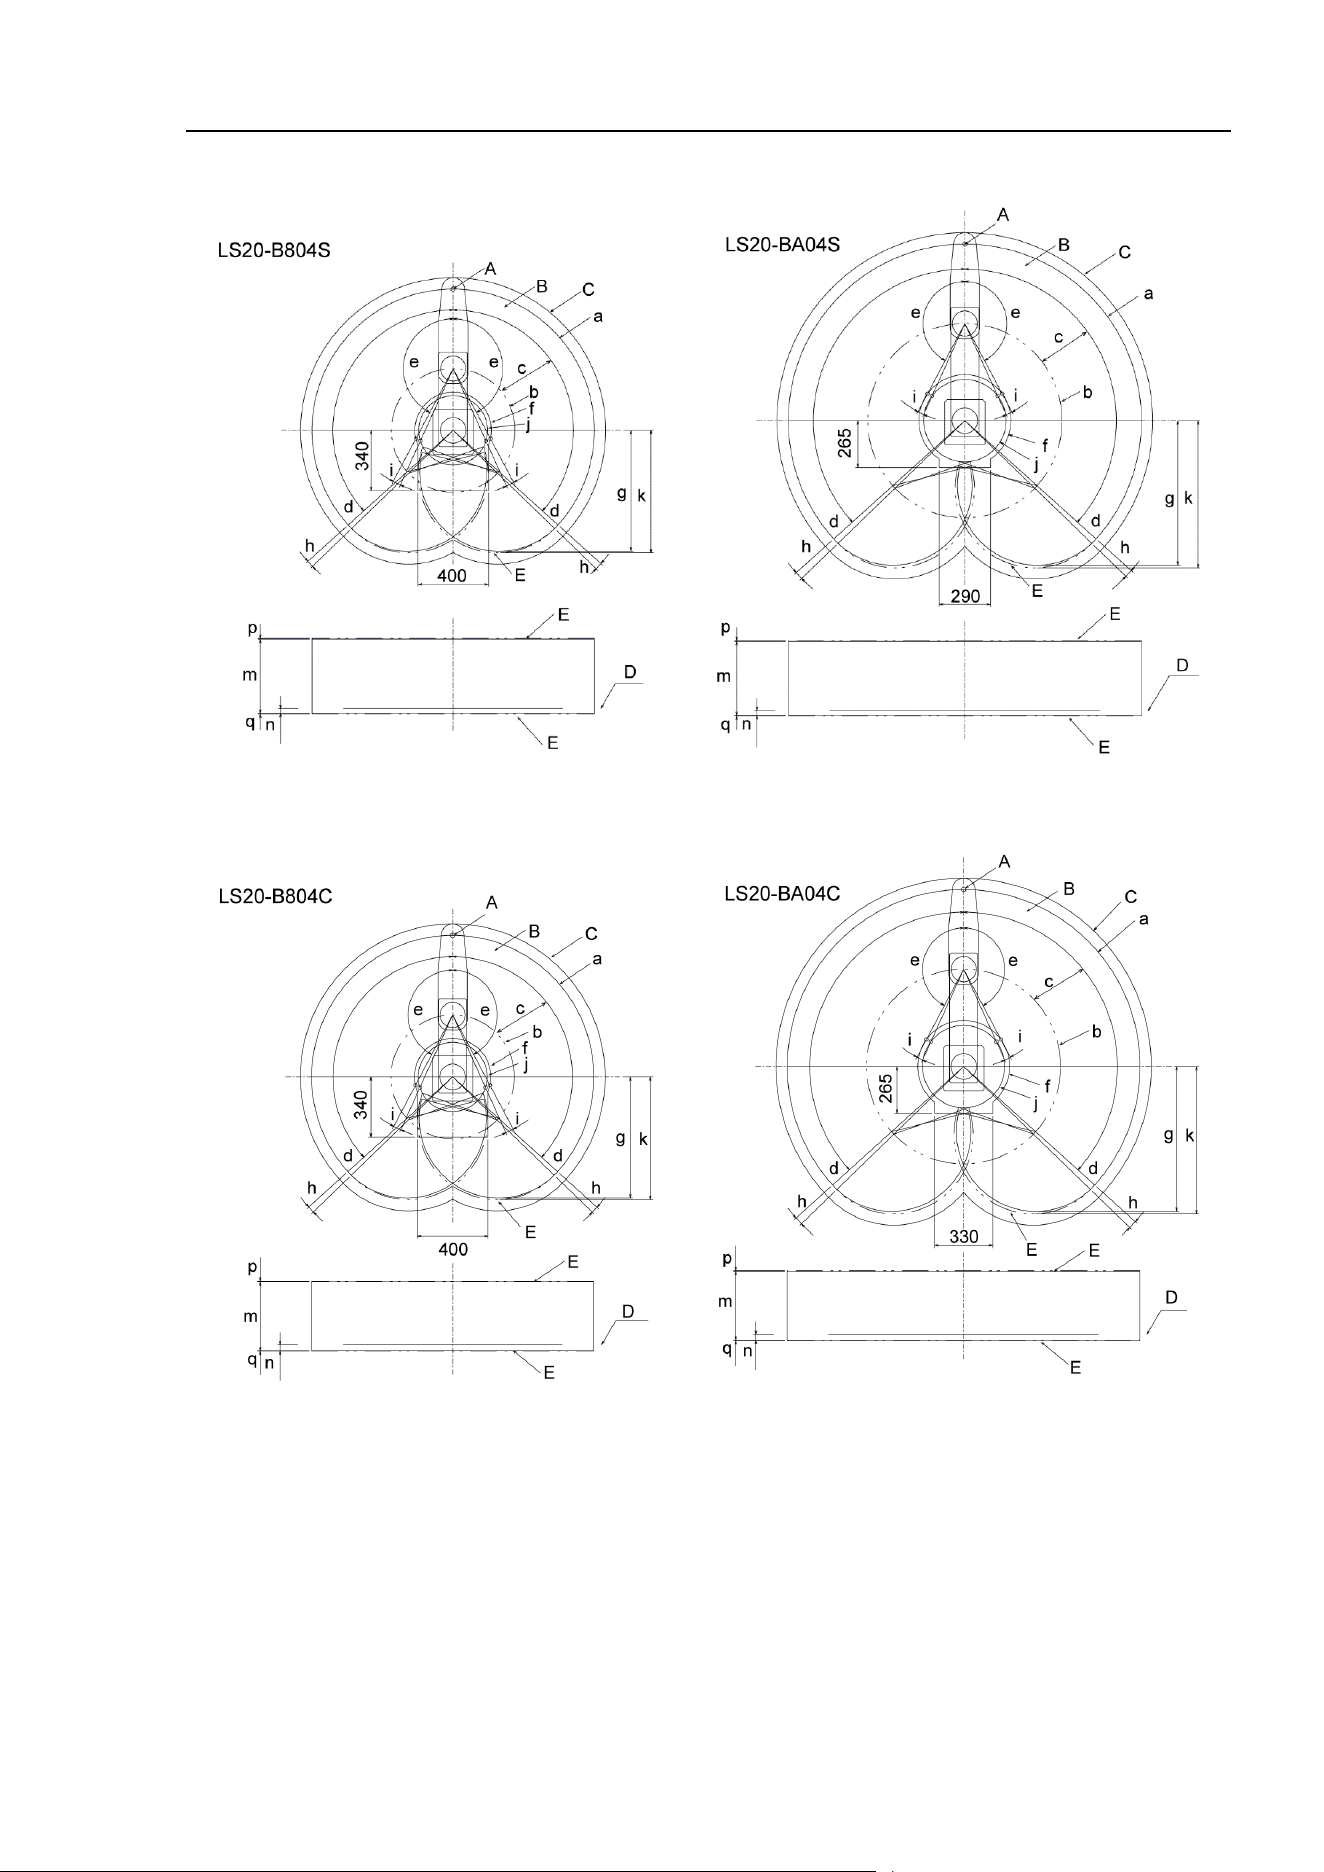
Setup & Operation 5. Motion Range
LS20-B Rev.4 57
Standard-model
Cleanroom-model
Setup & Operation 5. Motion Range
58
LS20-B Rev.4
Maintenance
This volume contains maintenance procedures with safety precautions
for LS20-B series Manipulators.
Maintenance 1. Safety Maintenance
LS20-B Rev.4 61
1. Safety Maintenance
Please read this chapter, this manual, and other relevant manuals carefully to understand
safe maintenance procedures before performing any routine maintenance.
Only authorized personnel who have taken safety training should be allowed to
maintain the robot system.
Safety training is the program for industrial robot operators that follows the laws
and regulations of each nation.
The personnel who have taken safety training acquire knowledge of industrial
robots (operations, teaching, etc.), knowledge of inspections, and knowledge of
related rules/regulations.
The personnel who have completed the robot system-training and maintenance-
training classes held by the manufacturer, dealer, or locally-incorporated company
are allowed to maintain the robot system.
WARNING
■
Do not
remove any parts that are not covered in this manual. Follow the
maintenance procedure strictly as described in this manual. Improper removal
of parts or
improper maintenance may not only cause improper function of the
robot system but also serious safet
y problems.
■
Keep away from the Manipulator while
the power is ON if you have not taken the
training courses.
Do not enter the operating area while the power
is ON.
Entering the operating area with the power ON is extremely hazardous and may
cause serious safety problems as the Manipulator may move
even it seems to be
stopped
.
■
When you check the operation of the Manipulator a
fter replacing parts, be sure to
check it
while you are outside of the safeguarded area. Checking the operation
of the Manipulator while you are inside of the safeguarded area may cause serious
safety problems as the Manipulator may move unexpectedly.
■
Before
operating the robot system, make sure that both the Emergency Stop
switches and safeguard switch function properly.
Operating the robot system
when the switches do not function properly is extremely hazardous and may result
in serious bodily injury and/or serious damage
to the robot system as the switches
cannot fulfill
their intended functions in an emergency.
WARNING
■
To shut off power
to the robot system, disconnect the power plug from the power
source. Be sure to connect the AC power cable to a power receptacle.
DO NOT connect it directly to a factory power source.
■
Before performing any replacement procedure, turn OFF the Controller and
related equipment,
and then disconnect the power plug from the power source.
Performing any replacement procedure with the power ON is extremely hazardous
and may result in
electric shock and/or malfunction of the robot system.
Maintenance 2. General Maintenance
62
LS20-B R ev.4
CAUTION
■
Be sure to connect the cables properly.
Do not allow unnecessary strain on the
cables. (Do not
put heavy objects on the cables. Do not bend or pull the cables
forcibl
y.) The unnecessary strain on the cables may result in damage to the
cables,
disconnection, and/or contact failure. Damaged cables, disconnection,
or contact failure is extremely hazardous and may result in electric shock and/or
improper function of the robot system.
2. General Maintenance
This chapter describes maintenance inspections and procedures. Performing maintenance
inspections and procedures properly is essential for preventing trouble and ensuring safety.
Be sure to perform the maintenance inspections in accordance with the schedule.
2.1 Maintenance Inspection
2.1.1 Schedule for Maintenance Inspection
Inspection points are divided into five stages: daily, monthly, quarterly, biannual, and annual.
The inspection points are added every stage.
If the Manipulator is operated for 250 hours or longer per month, the inspection points must
be added every 250 hours, 750 hours, 1500 hours, and 3000 hours operation.
Inspection Point
Daily
inspection
Monthly
inspection
Quarterly
inspection
Biannual
inspection
Annual
inspection
Overhaul
(replacement)
1 month (250 h)
Inspect every day
√
2 months (500 h)
√
3 months (750 h)
√
√
4 months (1000 h)
√
5 months (1250 h)
√
6 months (1500 h)
√
√
√
7 months (1750 h)
√
8 months (2000 h)
√
9 months (2250 h)
√
√
10 months (2500 h)
√
11 months (2750 h)
√
12 months (3000 h)
√
√
√
√
13 months (3250 h)
√
…
…
…
…
…
…
…
20000 h
√
h = hour
Maintenance 2. General Maintenance
LS20-B Rev.4 63
2.1.2 Inspection Point
Inspection While the Power is OFF (Manipulator is not operating)
Inspection Point Inspection Place Daily Monthly
Quarterly
Biannual Annual
Check looseness or backlash of
bolts, screws.
Tighten them if necessary.
(For the tightening torque, refer to
Maintenance: 2.4 Tightening
Hexagon Socket Head Cap Bolts.)
End effector mounting bolts
√
√
√
√
√
Manipulator mounting bolts
√
√
√
√
√
Each arm locking bolts
√
√
√
√
√
Bolts, screws around shaft
√
Bolts, screws securing motors
,
reduction gear units, etc.
√
Check looseness of connectors.
If the connectors are loosen, push it
securely or tighten.
External connectors on
Manipulator (on the connector
plates etc.)
√ √ √ √ √
Manipulator cable unit
√
√
√
√
Visually check for external defects.
Clean up if necessary.
External appearance of
Manipulator
√ √ √ √ √
External cables
√
√
√
√
Check for bends or improper
location. Repair or place it properly
if necessary.
Safeguard etc. √ √ √ √ √
Check tension of timing belts.
Tighten it if necessary.
Inside of Arm #2 √ √
Grease conditions
Refer to Maintenance: 2.3 Greasing.
Inspection While the Power is ON (Manipulator is operating)
Inspection Point
Inspection Place
Daily
Monthly
Quarterly
Biannual
Annual
Check motion range
Each joint
√
Check whether unusual sound or
vibration occurs.
Whole √ √ √ √ √
Measure the accuracy repeatedly by
a gauge.
Whole √
Turn ON and OFF the brake release
switch and check the sound of the
electromagnetic brake. If there is
no sound, replace the brake.
Brake √ √ √ √ √
Maintenance 2. General Maintenance
64
LS20-B R ev.4
2.2 Overhaul (Parts Replacement)
CAUTION
■
Overhaul timing is based on an assumption that all joints are operated for equal
distance. If a particular joint has a
high duty or high load, it is recommended to
overhaul all joints (as many as possible) before exceeding 20,000 operation hours
with the joint as a basis.
The parts for the manipulator joints may cause accuracy decline or malfunction due to
deterioration of the manipulator resulting from long term use. In order to use the
manipulator for a long term, it is recommended to overhaul the parts (parts replacement).
The time between overhauls is 20,000 operation hours of the Manipulator as a rough
indication.
However, it may vary depending on usage condition and degree of the load (such as when
operated with the maximum motion speed and maximum acceleration / deceleration in
continuous operation) applied on the Manipulator.
Recommended replacement time for the parts subject to maintenance (motors, reduction
gear units, and timing belts) can be checked in the [Maintenance] dialog box box of the
EPSON RC+ 7.0.
For details, refer to the following manual.
Robot Controller RC90 /RC90-B Maintenance 6. Alarm
Note:
The recommended replacement time for the maintenance parts is when it reaches the L10
life (time until 10% failure probability). In the [Maintenance] dialog box box, the L10
life is displayed as 100%.
NOTE
Maintenance 2. General Maintenance
LS20-B Rev.4 65
The manipulator operation hours can be checked in [Controller Status Viewer] dialog box -
[Motor On Hours].
(1) Select EPSON RC+ menu-[Tools]-[Controller] to open the [Controller Tools] dialog
box.
(2) Click the <View Controller Status> button to open the [Browse For Folder] dialog
box.
(3) Select the folder where the information is stored.
(4) Click <OK> to view the [Controller Status Viewer] dialog box.
(5) Select [Robot] from the tree menu on the left side.
For the parts subject to overhaul, refer to Maintenance 14. Maintenance Parts List.
For details on replacement of each part, refer to the Maintenance section.
Please contact the supplier of your region for further information.
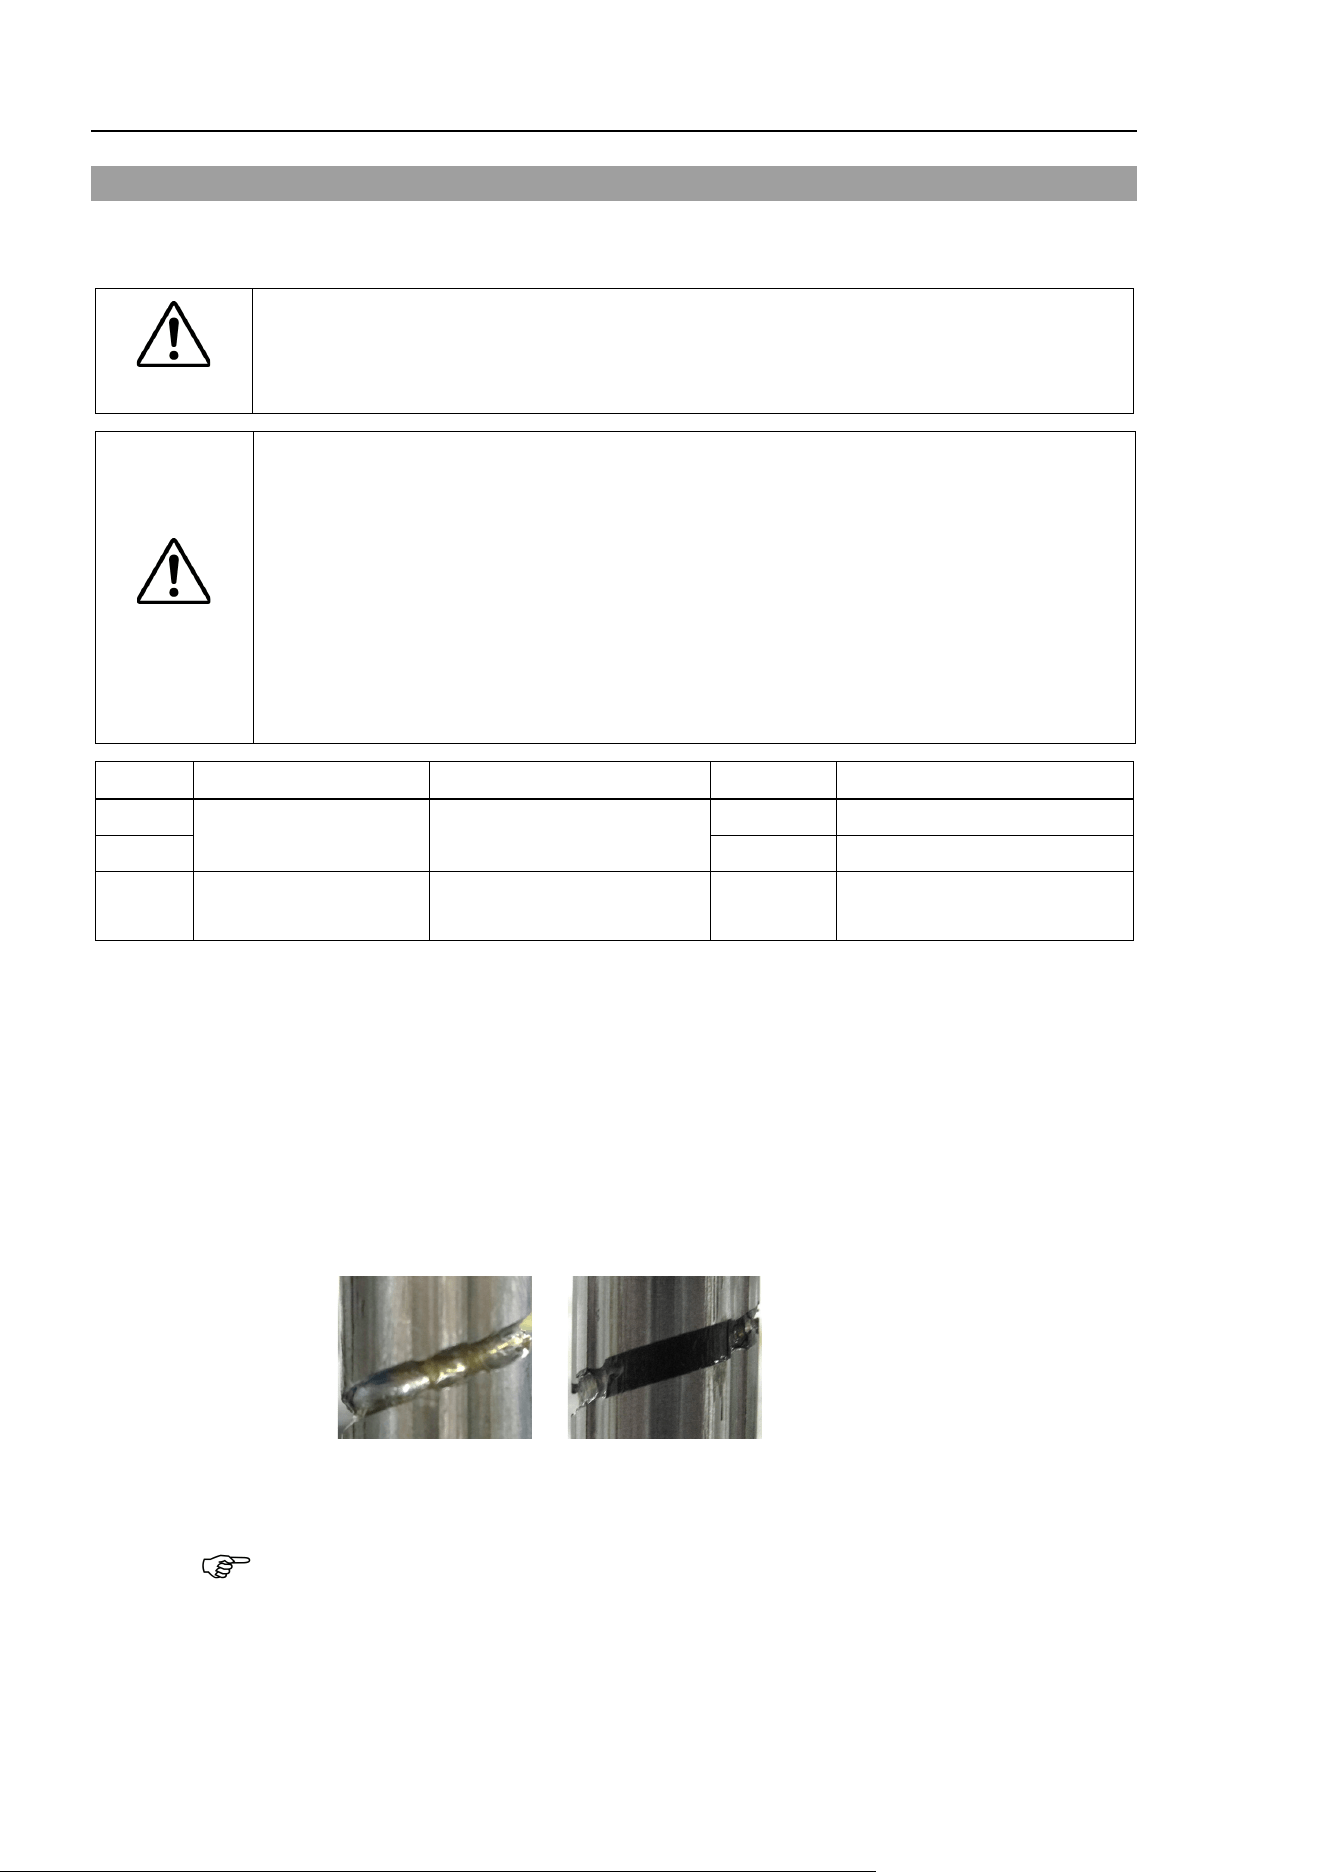
Maintenance 2. General Maintenance
66
LS20-B R ev.4
2.3 Greasing
The ball screw spline and reduction gear units need greasing regularly. Only use the grease
specified in the following table.
CAUTION
■
Keep enough grease in the Manipulator.
Operating the Manipulator with
insufficient
grease will damage sliding parts and/or result in insufficient function of
the Manipulator
. Once the parts are damaged, a lot of time and money will be
required for the repairs.
C
AUTION
■
If grease gets into your eyes, mouth, or on your skin, follow the instructions below.
I
f grease gets into your eyes
: Flush them thoroughly with clean water, and then see a doctor
immediately.
If grease gets into your mouth
: If swallowed, do not induce vomiting. See a doctor immediately.
: If grease just gets into your mouth, wash out your mouth with water
thoroughly.
If grease gets on your skin
: Wash the area thoroughly with soap and water.
Greasing part
Greasing Interval
Grease
Refer to Maintenance:
Joint #1
Reduction gear units Overhaul timing
SK-1A
5. Joint #1
Joint #2
SK-1A
6. Joint #2
Joint #3 Ball screw spline unit
At 100 km of operation
(50 km for first greasing)
AFB
10. Greasing
the Ball Screw Spline Unit
Joint #1, 2 reduction gear units
As a rough indication, perform greasing at the same timing as overhaul.
However, it may vary depending on usage condition and degree of the load (such as when
operated with the maximum motion speed and maximum acceleration / deceleration in
continuous operation) applied on the Manipulator.
Joint #3 Ball screw spline unit
The recommended greasing interval is at 100 km of operation. However, greasing timing
also can be checked from the grease condition. Perform greasing if the grease is
discolored or becomes dry.
Normal grease Discolored grease
Perform greasing at 50 km of operation for the first time of greasing.
Recommended replacement time for the grease on the ball screw spline unit can be
checked in the [Maintenance] dialog box box of the EPSON RC+ 7.0.
For details, refer to the following manual.
Robot Controller RC90 / RC90-B Maintenance 6. Alarm
NOTE
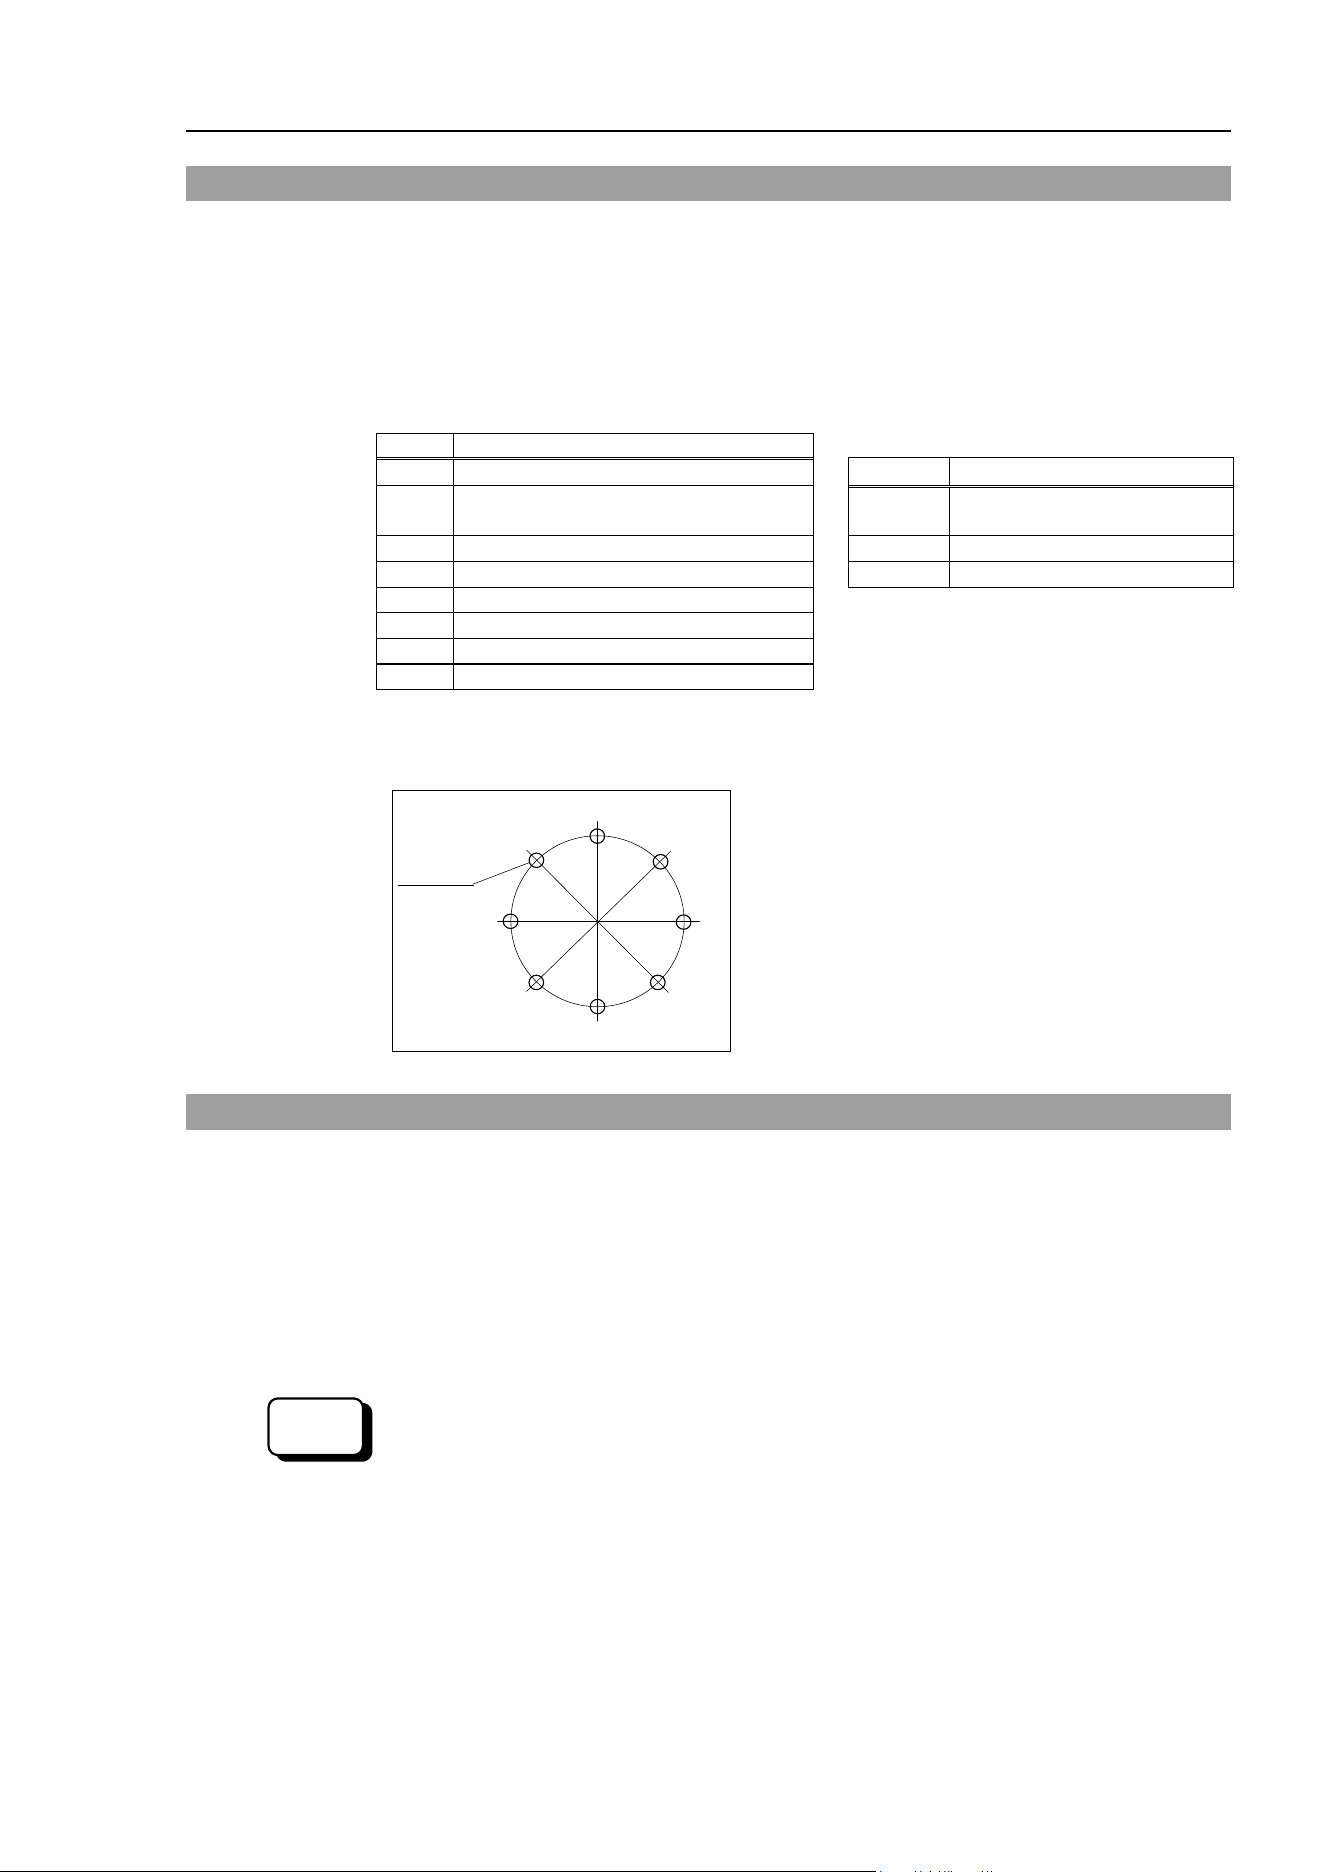
Maintenance 2. General Maintenance
LS20-B Rev.4 67
2.4 Tightening Hexagon Socket Head Cap Bolts
Hexagon socket head cap bolts are used in places where mechanical strength is required.
(A hexagon socket head cap bolt will be called a “bolt” in this manual.) These bolts are
fastened with the tightening torques shown in the following table.
When it is necessary to refasten these bolts in some procedures in this manual (except special
cases as noted), use a torque wrench so that the bolts are fastened with the appropriate
tightening torques as shown below.
Bolt
Tightening Torque
Refer below for the set screw.
M2.5
1.4 ± 0.1 N⋅m
(14 ± 1 kgf⋅cm)
Bolt
Tightening Torque
M3
2.0 ± 0.1 N⋅m
(21
± 1 kgf⋅cm)
M3
0.7 ± 0.1 N⋅m
(7.1 ± 1
kgf⋅cm)
M4
4.0 ± 0.2 N⋅m
(41 ± 2 kgf⋅cm)
M4
2.4 ± 0.1 N⋅m
(26 ± 1 kgf⋅cm)
M5
8.0 ± 0.4 N⋅m
(82 ± 4 kgf⋅cm)
M5
3.9 ± 0.2 N⋅m
(40 ± 2 kgf⋅cm)
M6
13.0 ± 0.6 N⋅m
(133 ± 6 kgf⋅cm)
M8
32.0 ± 1.6 N⋅m
(326 ± 16 kgf⋅cm)
M10
58.0 ± 2.9 N⋅m
(590 ± 30 kgf⋅cm)
M12
100.0 ± 5.0 N⋅m
(1,020 ± 51 kgf⋅cm)
The bolts aligned on a circumference should be fastened in a crisscross pattern as shown in
the figure below.
1
5
3
7
2
6
4
8
Bolt hole
Do not fasten all bolts securely at one time. Divide
the number of times that the bolts are fastened into
two or three and fasten the bolts securely with a
hexagonal wrench. Then, use a torque wrench so
that the bolts are fastened with tightening torques
shown in the table above.
2.5 Matching Origins
After parts have been replaced (motors, reduction gear units, a brake, timing belts, a ball
screw spline unit, etc.), the Manipulator cannot operate properly because a mismatch exists
between the origin stored in each motor and its corresponding origin stored in the Controller.
After replacing the parts, it is necessary to match these origins.
For calibration, the pulse values for a specific position must be recorded in advance.
Before replacing parts, select easy point (pose) data from the registered point data to check
the accuracy. Then, follow the steps below to display the pulse values and record them.
Execute the following
command from the [Command Window].
>PULSE
PULSE: [Joint #1 Pulse value] pls [Joint #2 Pulse value] pls
[Joint #3 Pulse value]
pls [Joint #4 Pulse value] pls
EPSON
RC+
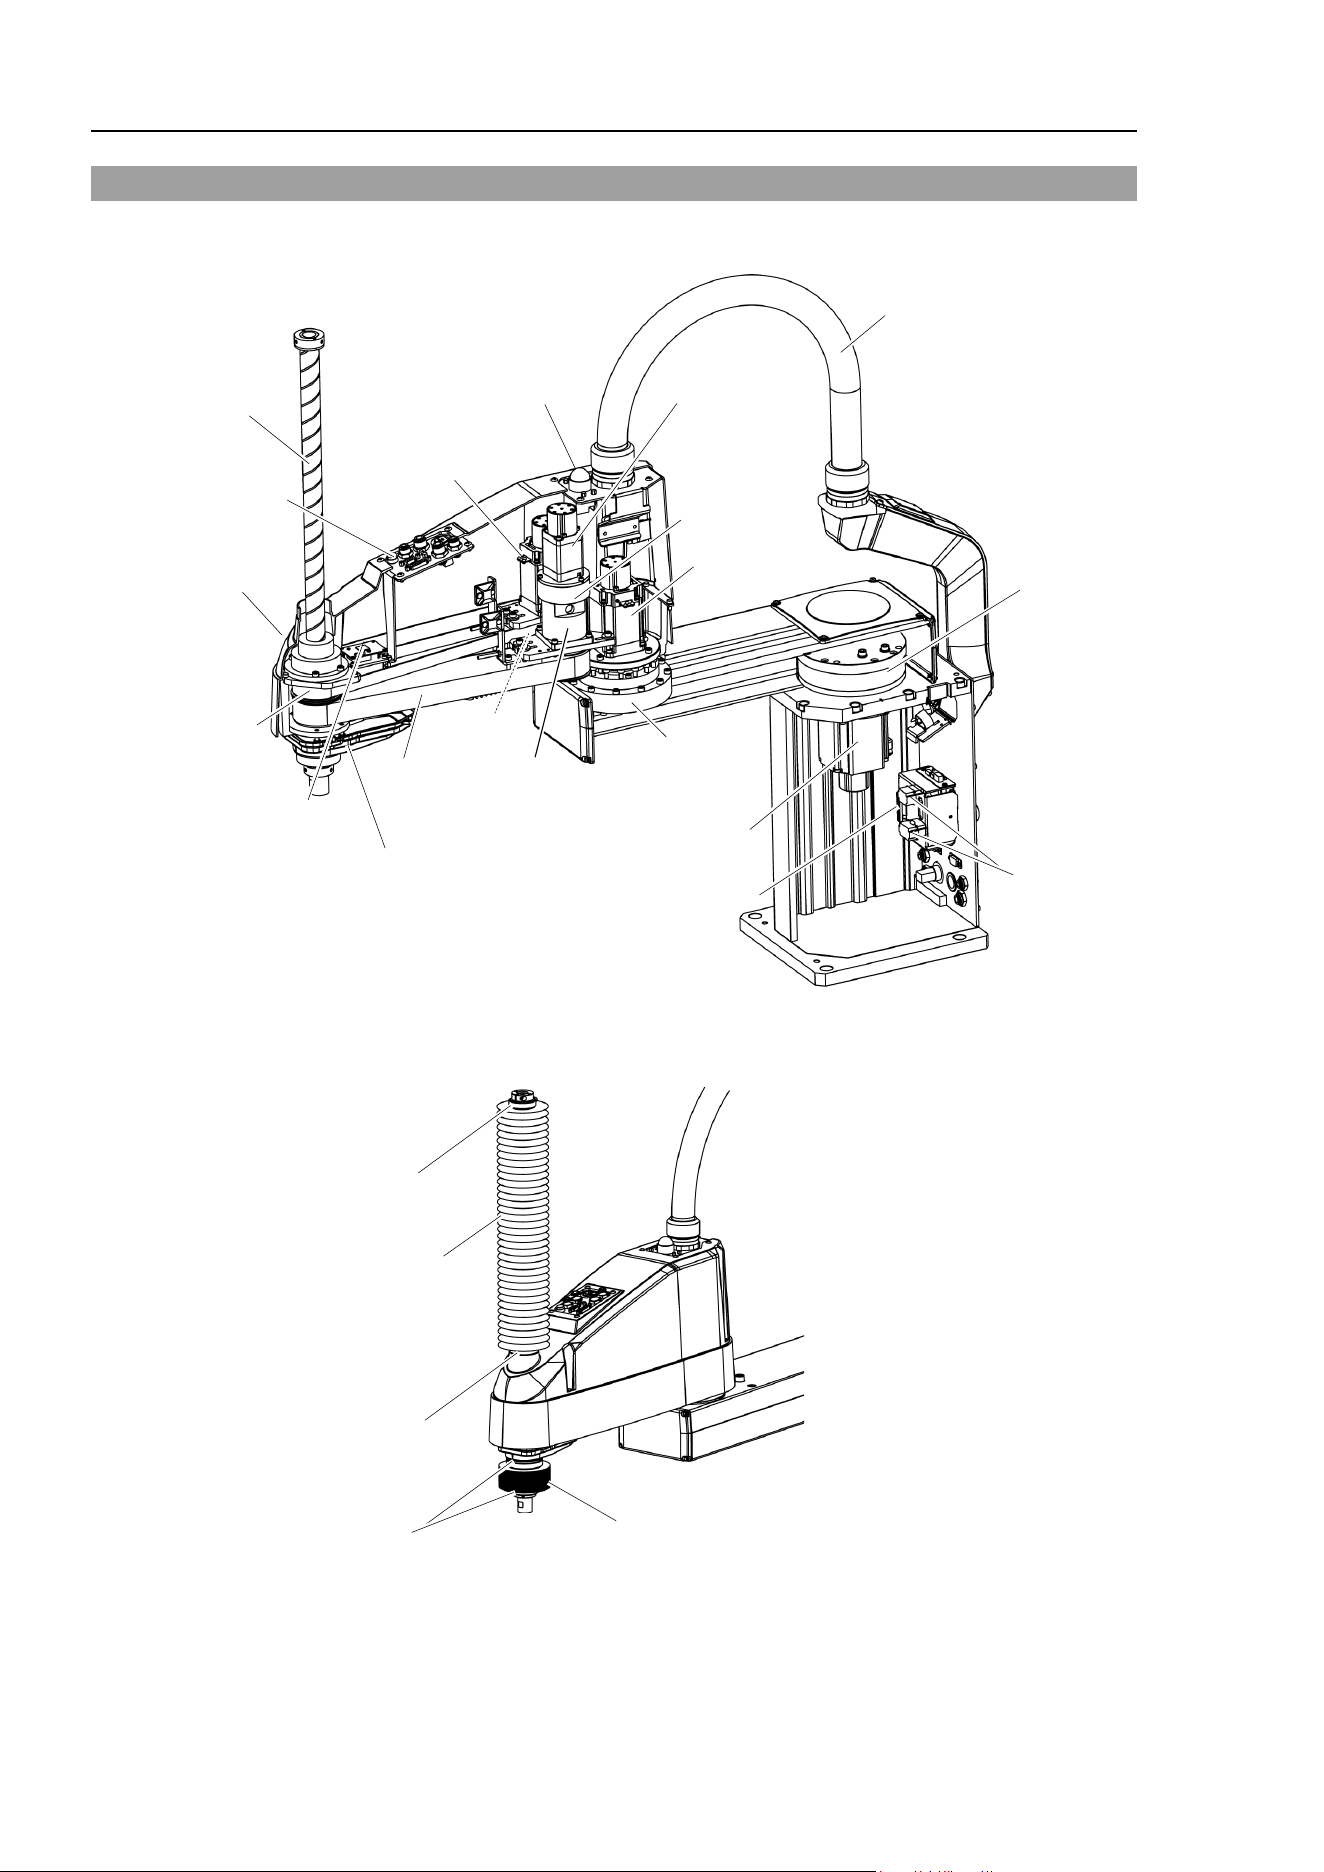
Maintenance 2. General Maintenance
68
LS20-B R ev.4
2.6 Layout of Maintenance Parts
Standard-model
Power Cable
Cable Unit
Signal Cable
Brake Release
Switch
LED Lamp
Ball Screw Spline Unit
Arm Top Cover
Joint #3
Motor
Z Belt
U Belt
Joint #2
Motor
Joint #2
Reduction Gear
Unit
Joint #1
Reduction Gear
Unit
Joint #1 Motor
Joint #4
Motor
Control Board
Arm Bottom Cover
Joint #4
Brake
Joint #3
Brake
Joint #4
Reduction
Gear Unit
Cleanroom-model (with optional bellows)
For the Cleanroom-model, the following parts are added to the Standard-model.
Bellows
Bellows
Clamp Band
Clamp Band
Clamp Band
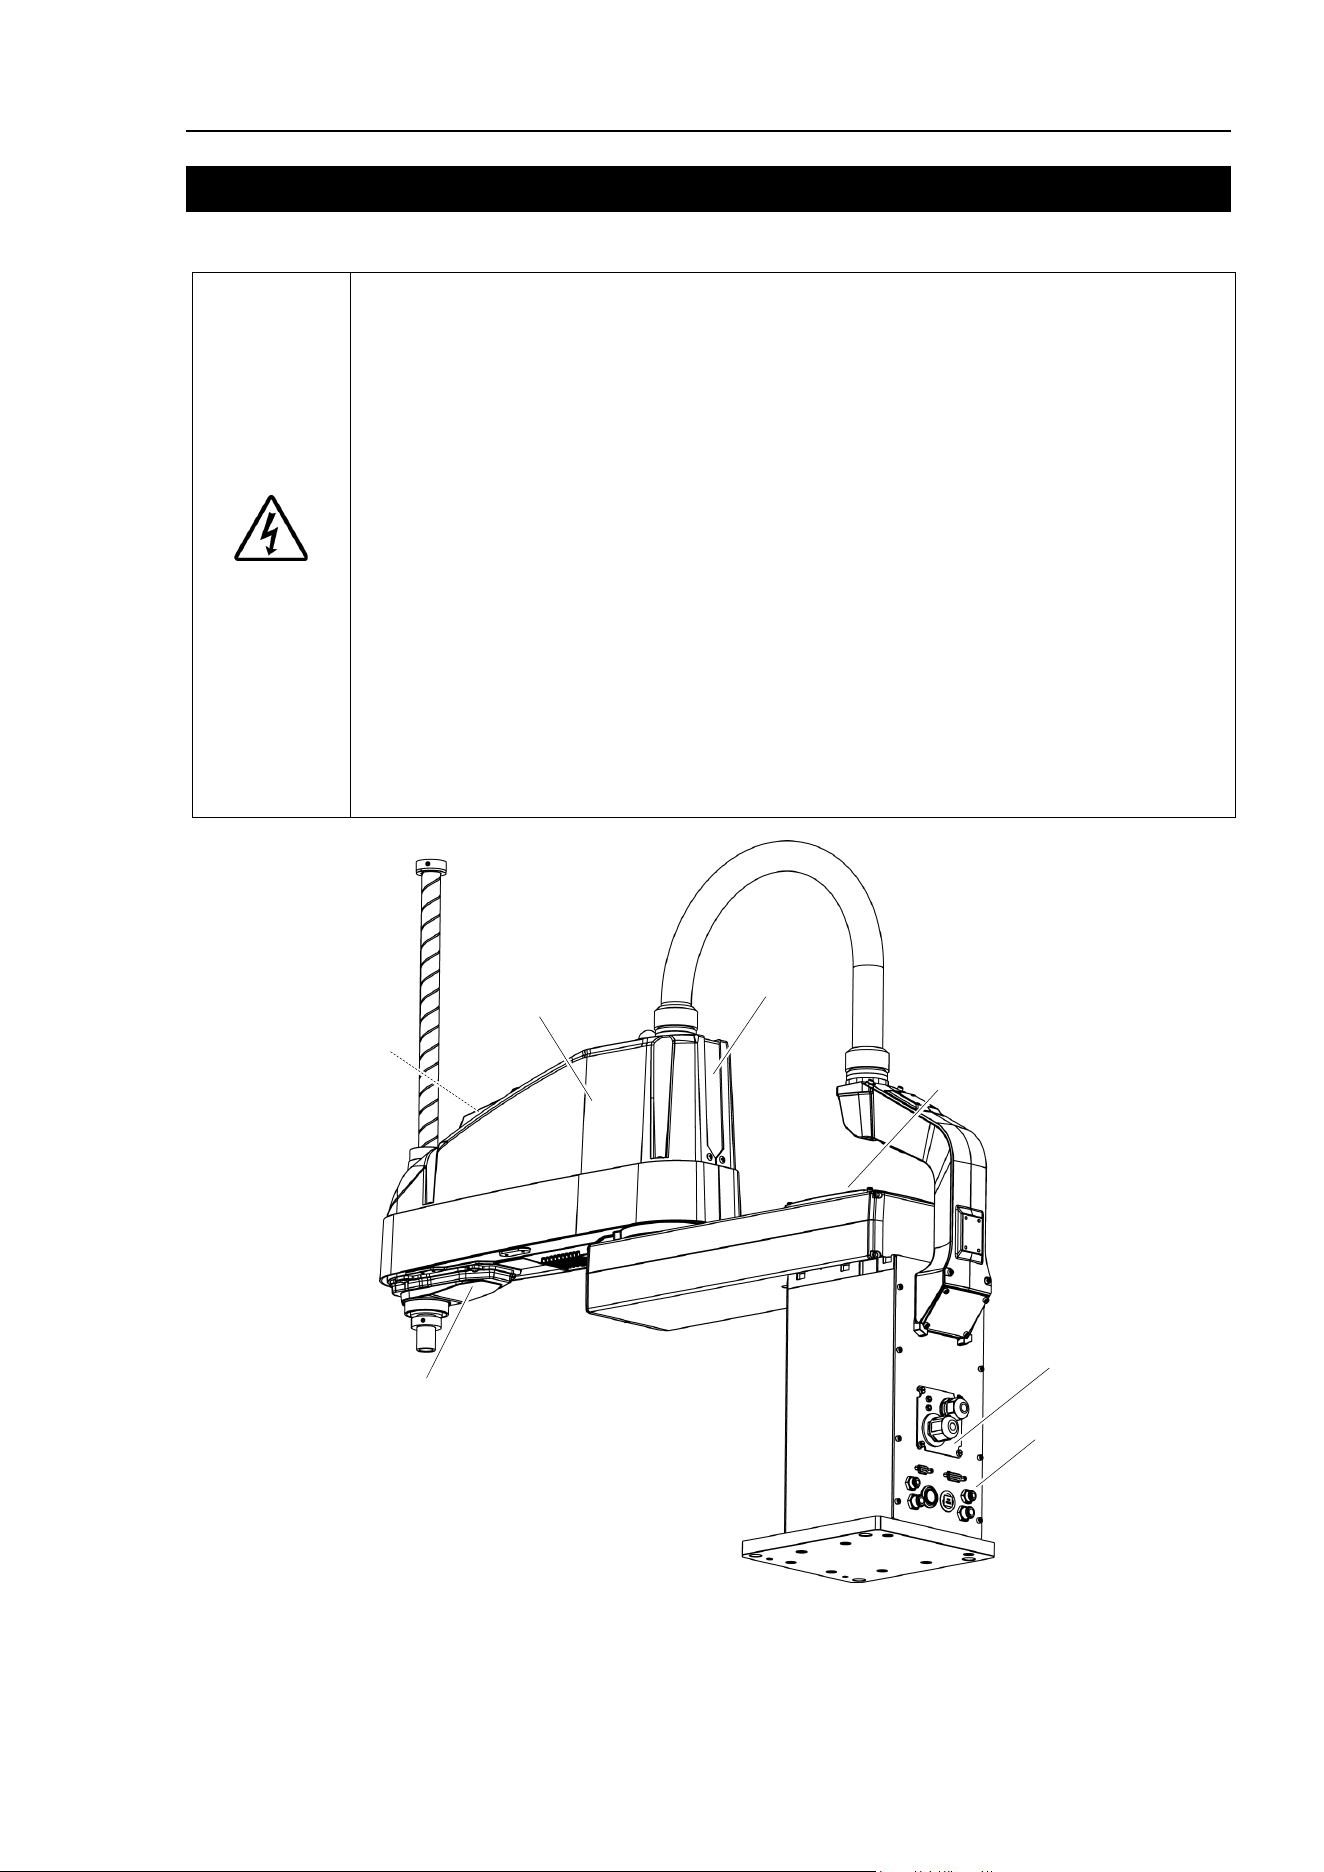
Maintenance 3. Covers
LS20-B Rev.4 69
3. Covers
All procedures for removing and installing covers in maintenance are described in this chapter.
WARNING
■
Do not connect or disconnect the motor connectors while the power to the robot
system is turned ON. Connecting or disconnecting the motor connectors
with the
power ON is extremely hazardous and may result
in serious bodily injury as the
Manipulator may mo
ve abnormally, and also may result in electric shock and/or
malfunction of the robot system.
■
To shut off power
to the robot system, disconnect the power plug from the power
source. Be sure to connect the AC power cable to a power receptacle.
DO NOT connect it directly to a factory power source.
■
Before performing any replacement procedure, turn OFF the Controller and related
equipment,
and then disconnect the power plug from the power source.
Performing any replacement procedure with the power ON is extremely hazardous
and may result in
electric shock and/or malfunction of the robot system.
■
Be careful not to get any foreign substances in
the Manipulator, connectors, and
pins during maintenance.
Turning ON the power to the robot system when any
foreign substances exist in them is extremely
hazardous and may result in electric
shock
and/or malfunction of the robot system.
Arm Bottom Cover
Connector Plate
Connector Sub Plate
Duct Plate
Arm Top Cover
Arm #1 Cover
User Plate
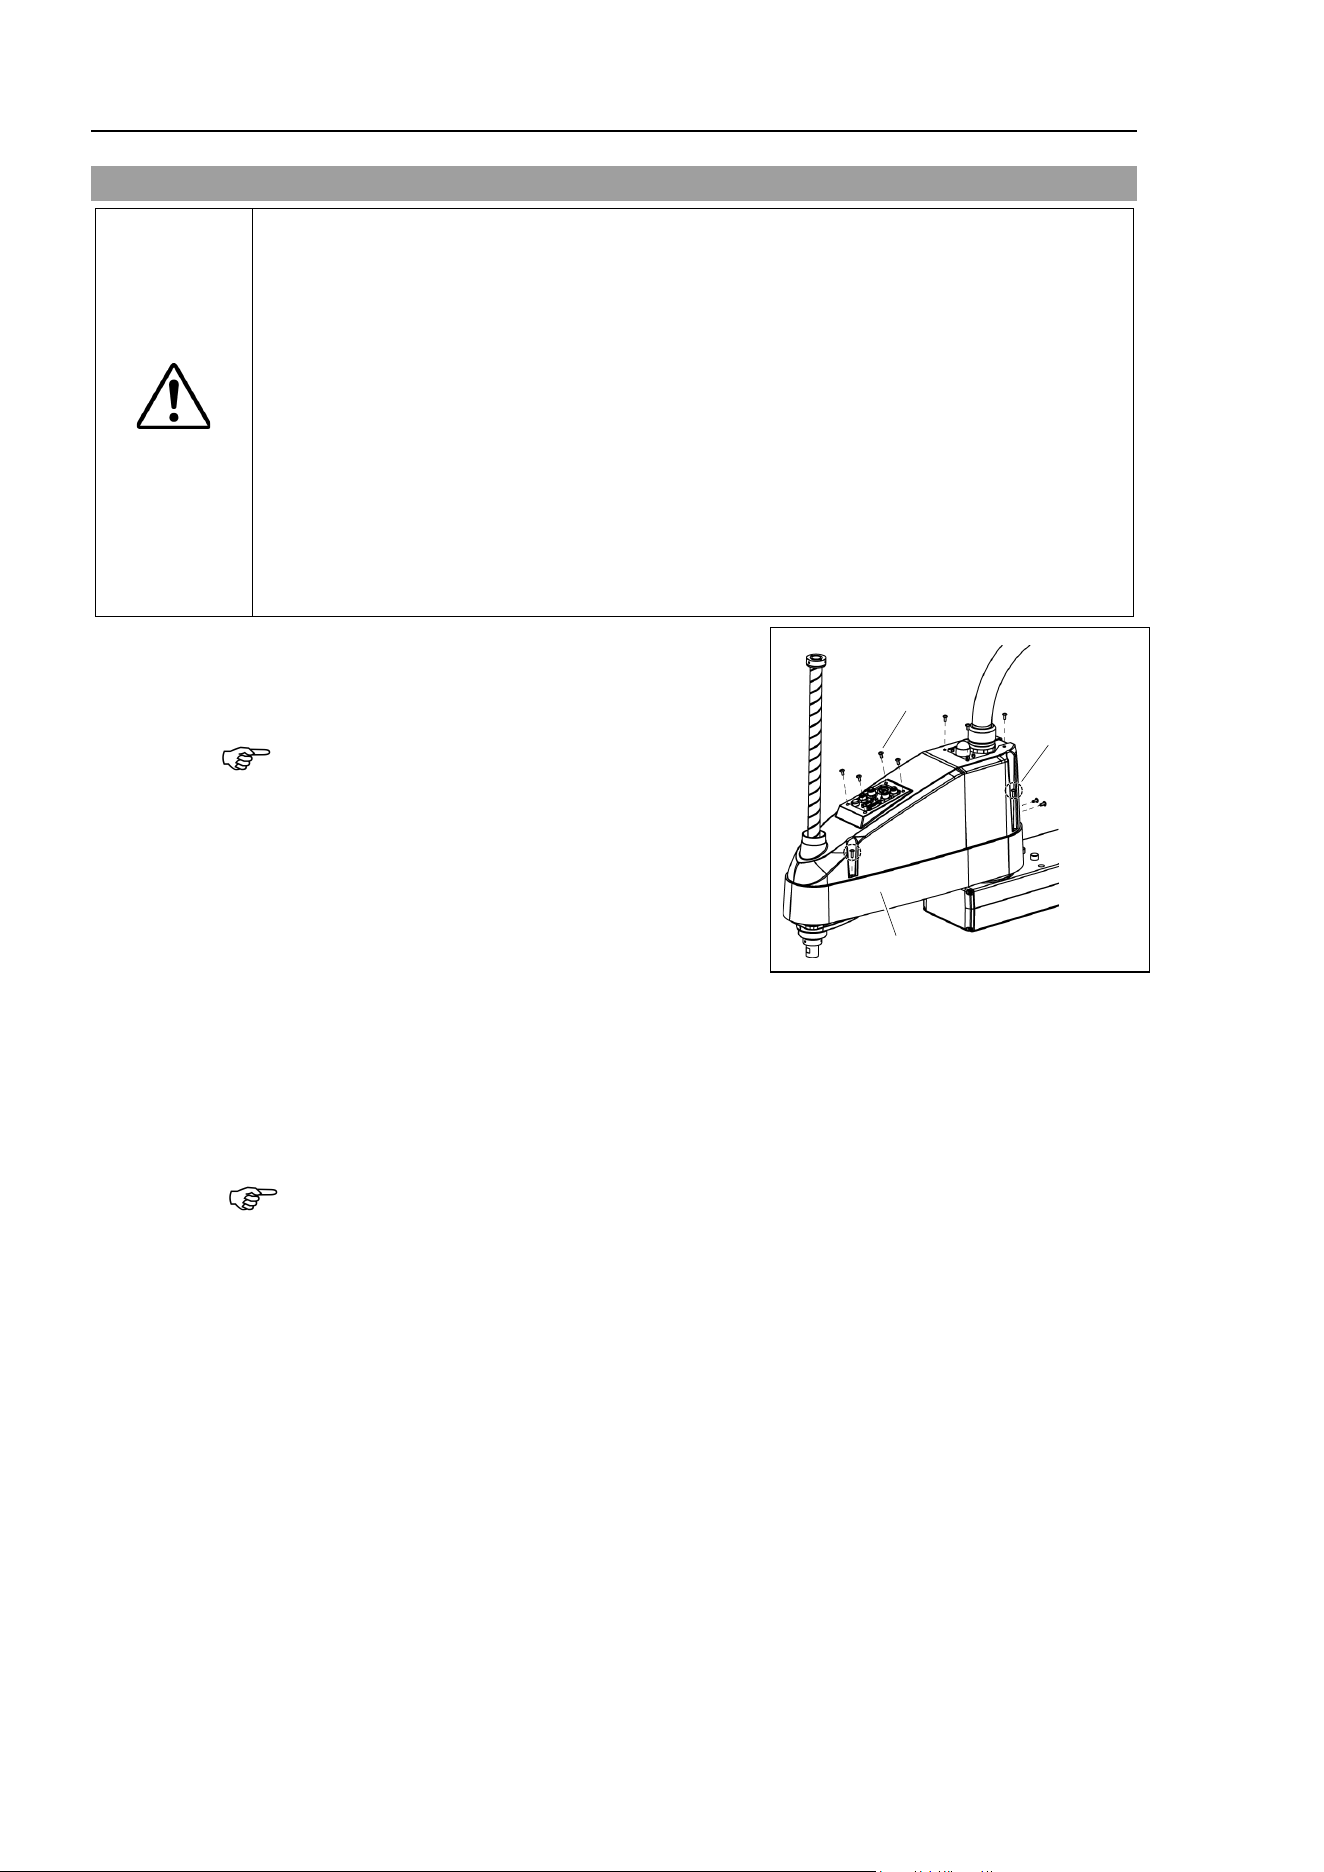
Maintenance 3. Covers
70
LS20-B R ev.4
3.1 Arm Top Cover
CAUTION
■
Do not remove the arm top cover
forcibly. Removing the cover forcibly may result
in damage to the cables, disconnection, and/or contact failure.
Damaged cables,
disconnection, or contact failure is extremely hazardous and may result in electric
shock and/or improper function of the robot system.
■
When mounting the cover, be careful not to allow the cables to interfere with the
cover mounting and
do not bend these cables forcibly to push them into the cover.
Unnecessary strain on cables may result in damage to the cables, disconnection,
and/or contact failure. Damaged cables, disconnection, or contact failure is
extremely hazardous and may resul
t in electric shock and/or improper function of
the robot system.
When
routing the cables, observe the cable locations
after removing the cover.
Be sure to
place the cables back to their original locations.
A
rm Top Cover
Removal
Unscrew the Arm Top Cover mounting bolts, and
then lift the cover.
When bellows are installed to the manipulator,
remove the upper bellows and then remove the
Arm Top Cover. For bellows removal, refer to
Maintenance 9. Bellows
.
Be careful for user
wires and tubes when
removing t
he cover.
Arm Top Cover
4-M4×14
Double sems
10-M4×10
Truss
Arm Top Cover
Installation
Put the arm top cover to the arm and secure with the Arm Top Cover mounting bolts.
After
securing the Arm Top Cover, make sure that the lower limit mechanical stop is not
touch
ing the cylindrical part of the Arm Top Cover.
Tightening torque: 0.45 N⋅m
When bellows are
installed to the manipulator, install the Arm Top Cover and then set the
upper bellows
. For bellows installation, refer to Maintenance 9. Bellows.
NOTE
NOTE
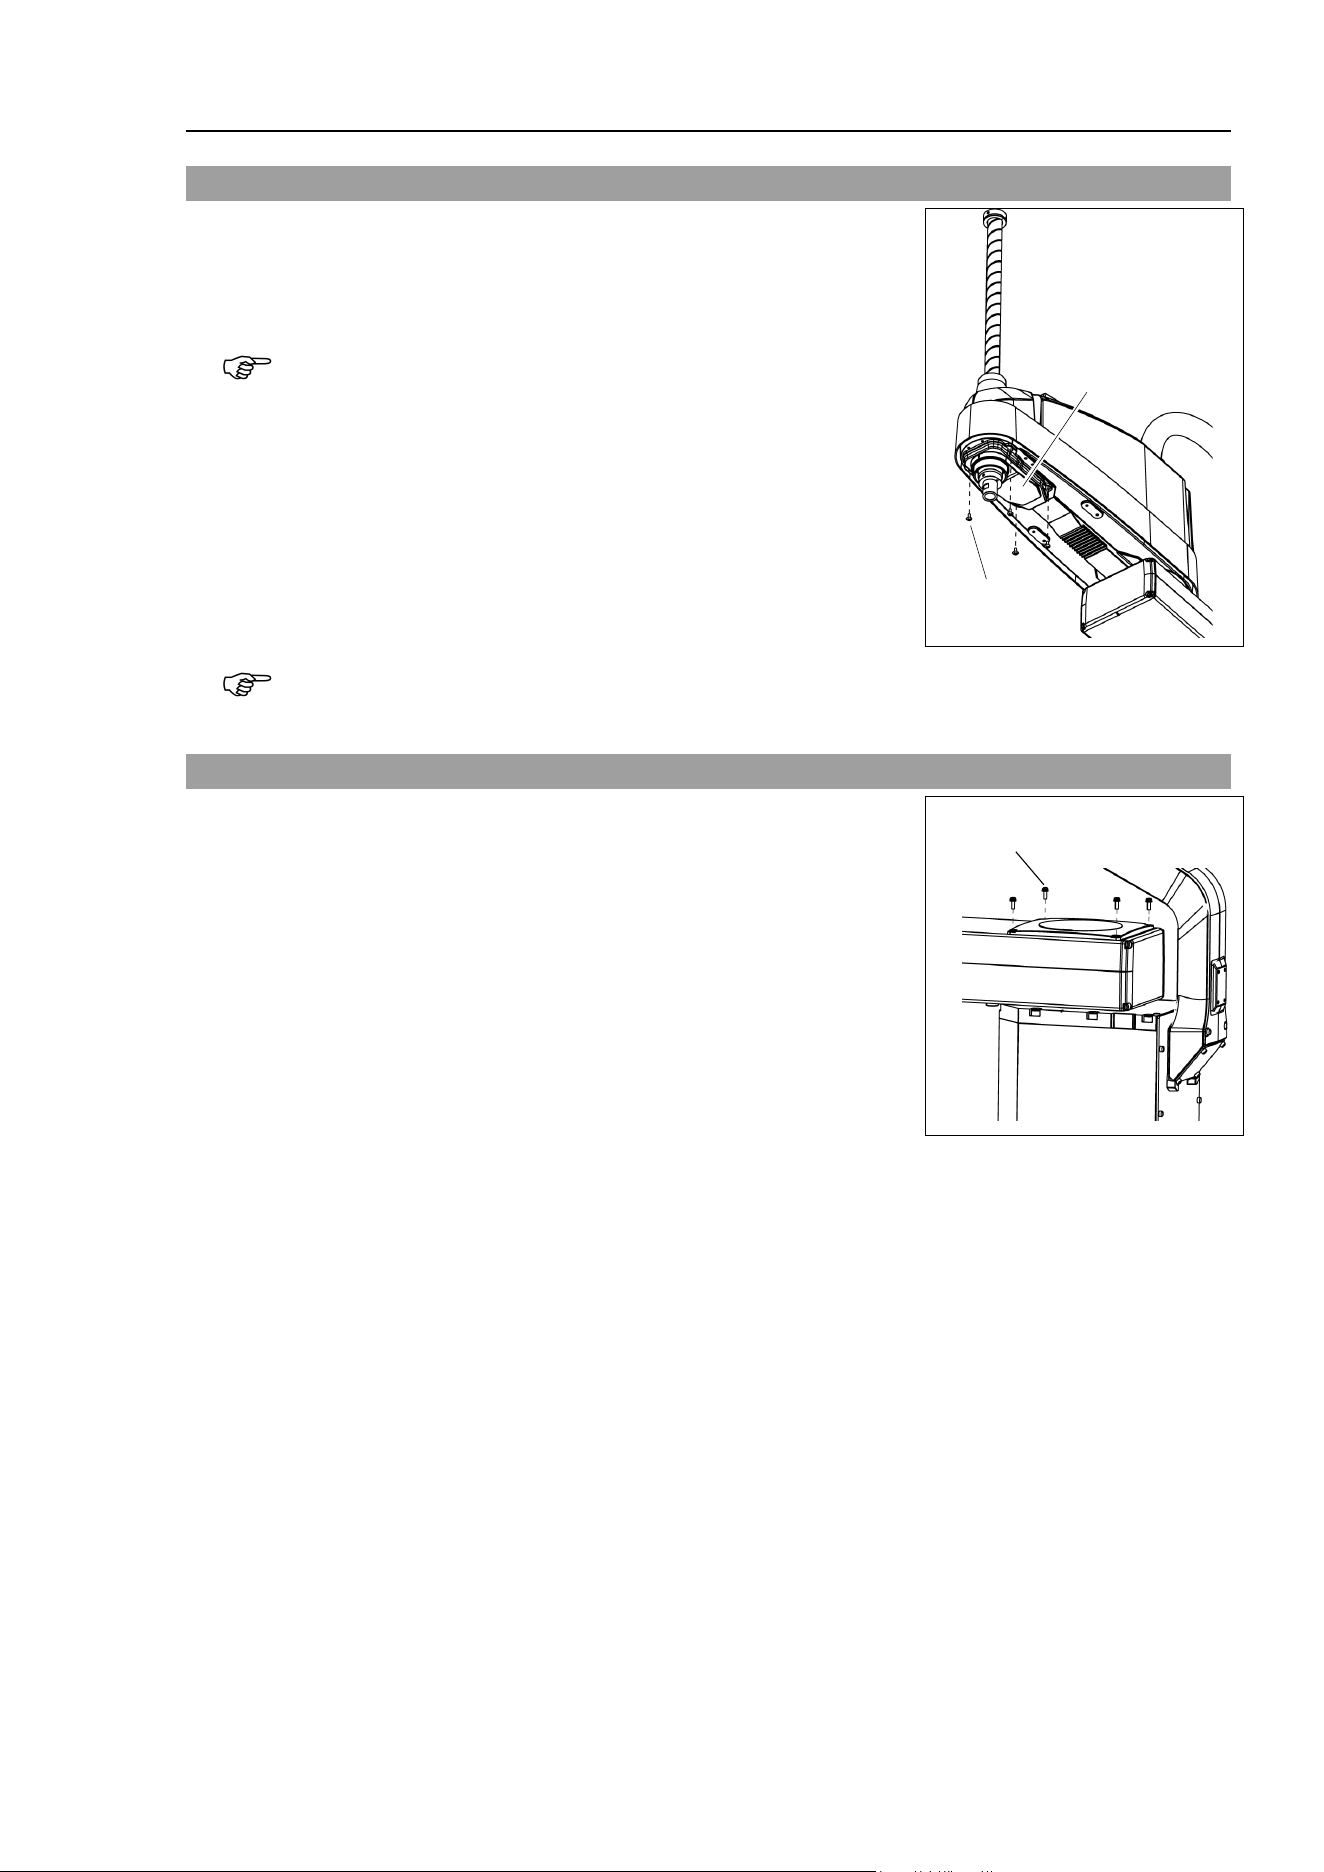
Maintenance 3. Covers
LS20-B Rev.4 71
3.2 Arm Bottom Cover
Unscrew the
Arm Bottom Cover mounting bolts and then remove
the cover.
Tightening torque: 0.45 N⋅m
Be careful of the
end effector. When the end effector is installed,
t
he Arm Bottom Cover may not be removed from the shaft.
When you replace the ball screw spline unit, y
ou need to remove
the end effector to remove the Arm Bottom Cover completely.
When you can work (maintenance, inspe
ction) without removing
the
cover completely, move the shaft to the lower limit and lower
the Arm Bottom C
over.
4-M4×10
Truss
Arm Bottom Cover
When bellows are installed to the manipulator, remove or pull down the lower bellows and then
remove the arm bottom cover. For bellows removal, refer to
Maintenance 9. Bellows.
3.3 Arm #1 Cover
U
nscrew the Arm #1 cover mounting bolts and remove
the
cover.
Tightening torque: 0.45 N⋅m
4-M4×12 Double sems
NOTE
NOTE
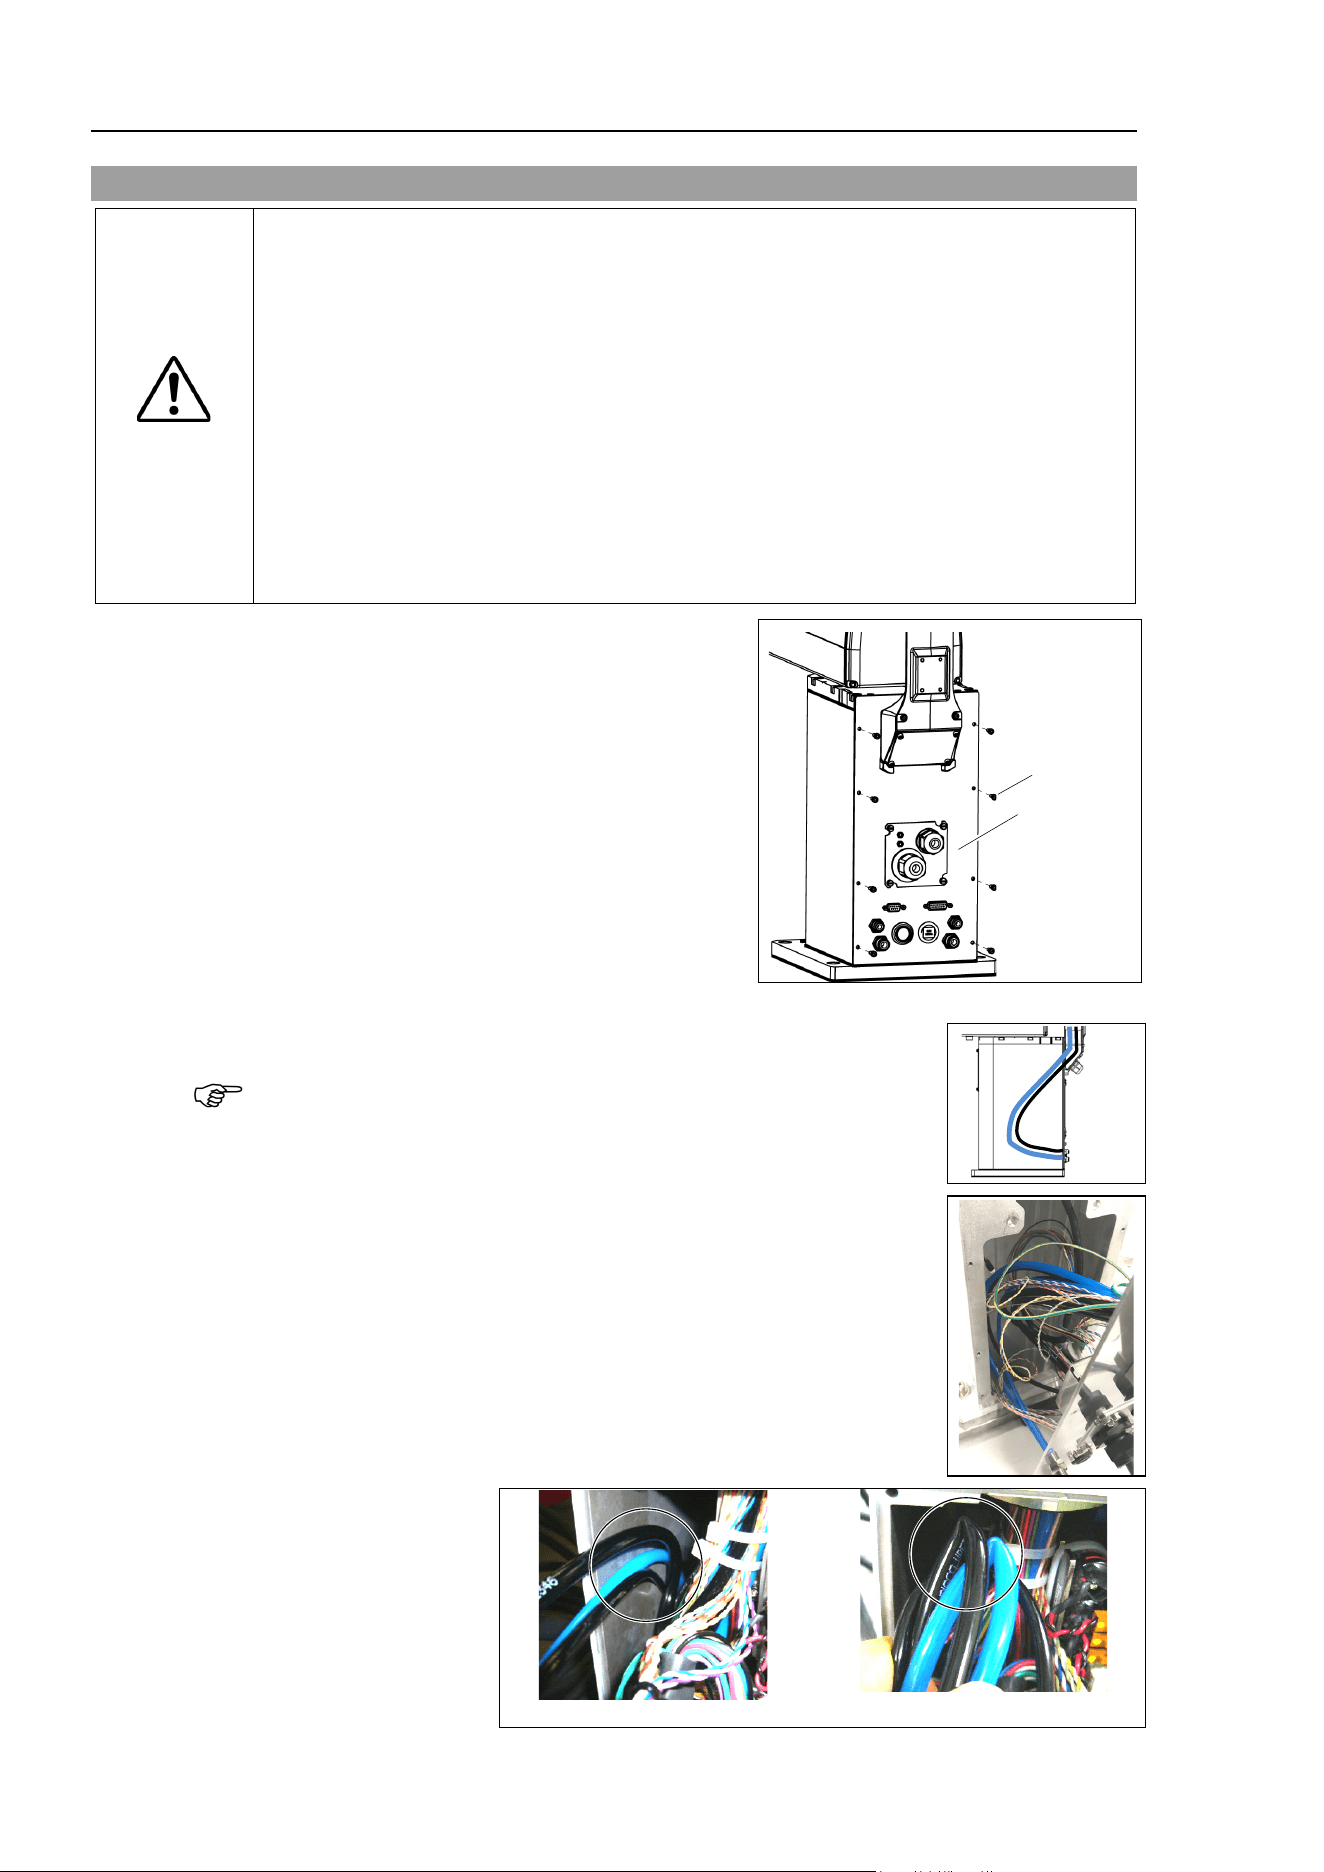
Maintenance 3. Covers
72
LS20-B R ev.4
3.4 Connector Plate
CAUTION
■
Do not remove the connector plate
forcibly. Removing the connector plate
forcibly may result in damage to the cables, disconnection, and/or contact failure.
Damaged cables, disconnection, or contact failure is extremely hazardous and
may result in electric shock and/or improper function of the robot system.
■
When mounting the connector plate, be careful not to allow the cables to interfere
with the plate mounting and d
o not bend these cables forcibly to push them into
the cover.
Unnecessary strain on cables may result in damage to the cables,
disconnection, and/or contact failure. Damaged cables, disconnection, or
contact failure
is extremely hazardous and may result in electric shock and/or
improper
function of the robot system. When routing the cables, observe the
cable location
s after removing the connector plate. Be sure to place the cables
back to their original locations
.
U
nscrew the Connector Plate mounting bolts
and remove the plate.
8-M4×10
Connector
Plate
When mounting the Connector Plate, be careful of the following.
Prevent the air tube from bending sharply inside
the manipulator.
Also, do not block the air flow.
If there is a kink in the air tube,
air flow is blocked while the
manipulator is operating and may cause a trouble.
Put the air tubes along the wall as shown in the picture.
GOOD: Curved
BAD: Bended
NOTE
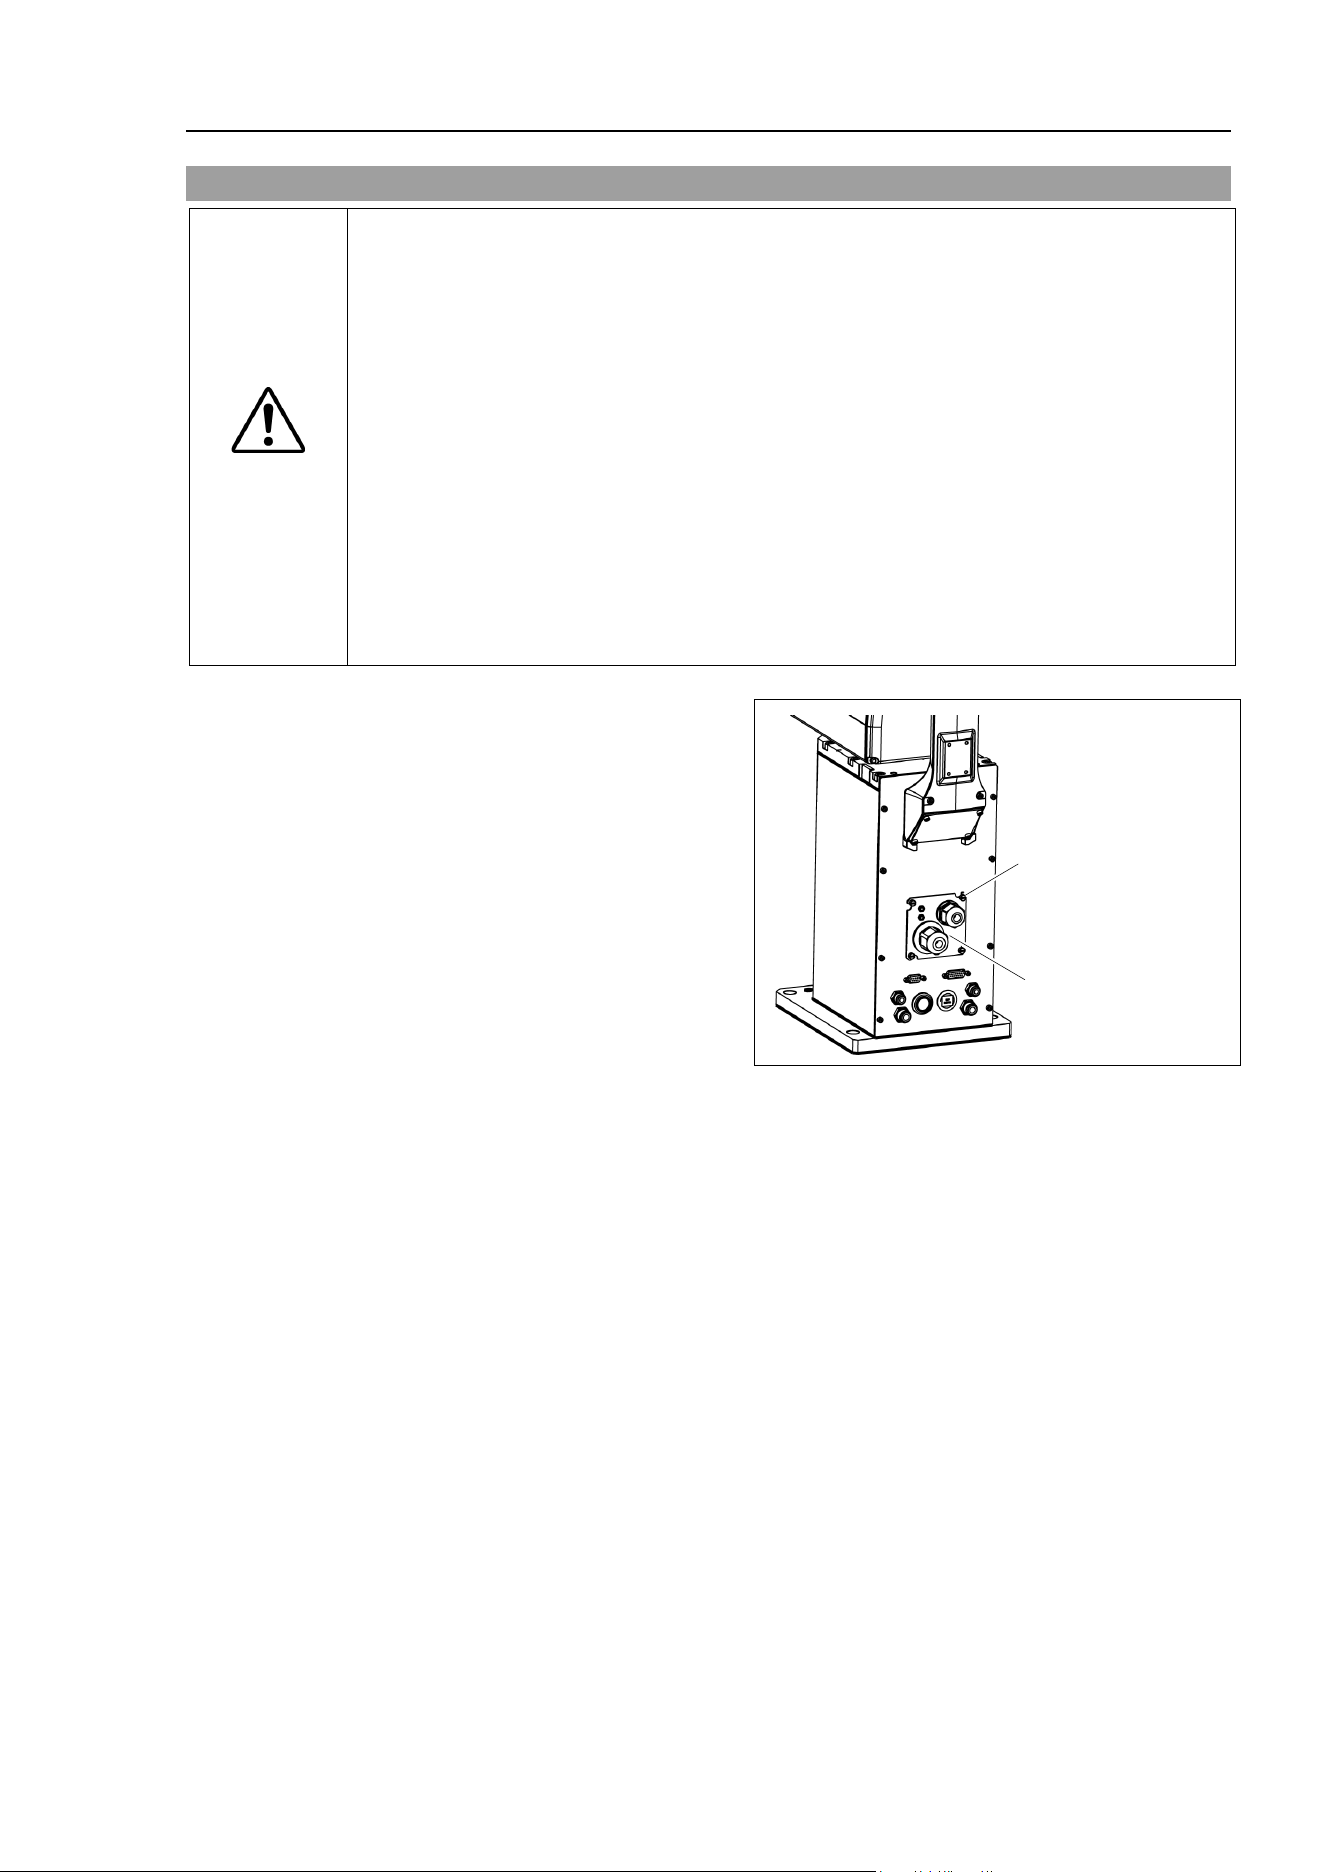
Maintenance 3. Covers
LS20-B Rev.4 73
3.5 Connector Sub Plate
CAUTION
■
Do not remove the connector sub plate
forcibly. Removing the connector sub
plate
forcibly may result in damage to the cables, disconnection, and/or contact
failure. Damaged cables, disconnection, or contact failure is extremely
hazardous and may result in electric shock and/or improper function of the robot
system.
■
When
mounting the connector sub plate, be careful not to allow the cables to
interfere with the plate mounting and d
o not bend these cables forcibly to push
them into the cover.
Unnecessary strain on cables may result in damage to the cables, disconnection,
and
/or contact failure. Damaged cables, disconnection, or contact failure is
extremely hazardous and may result in electric shock and/or improper
function of
the robot system.
When
routing the cables, observe the cable locations after removing the connector
sub plate
. Be sure to place the cables back to their original locations.
Unscrew the Connector Sub Plate
mounting bolts and remove the
plate.
Refer to
Setup&Operation 3.6
Connecting the Cables.
Connector
Sub Plate
4-M3×10
Finger Screws
(No need to unscrew)
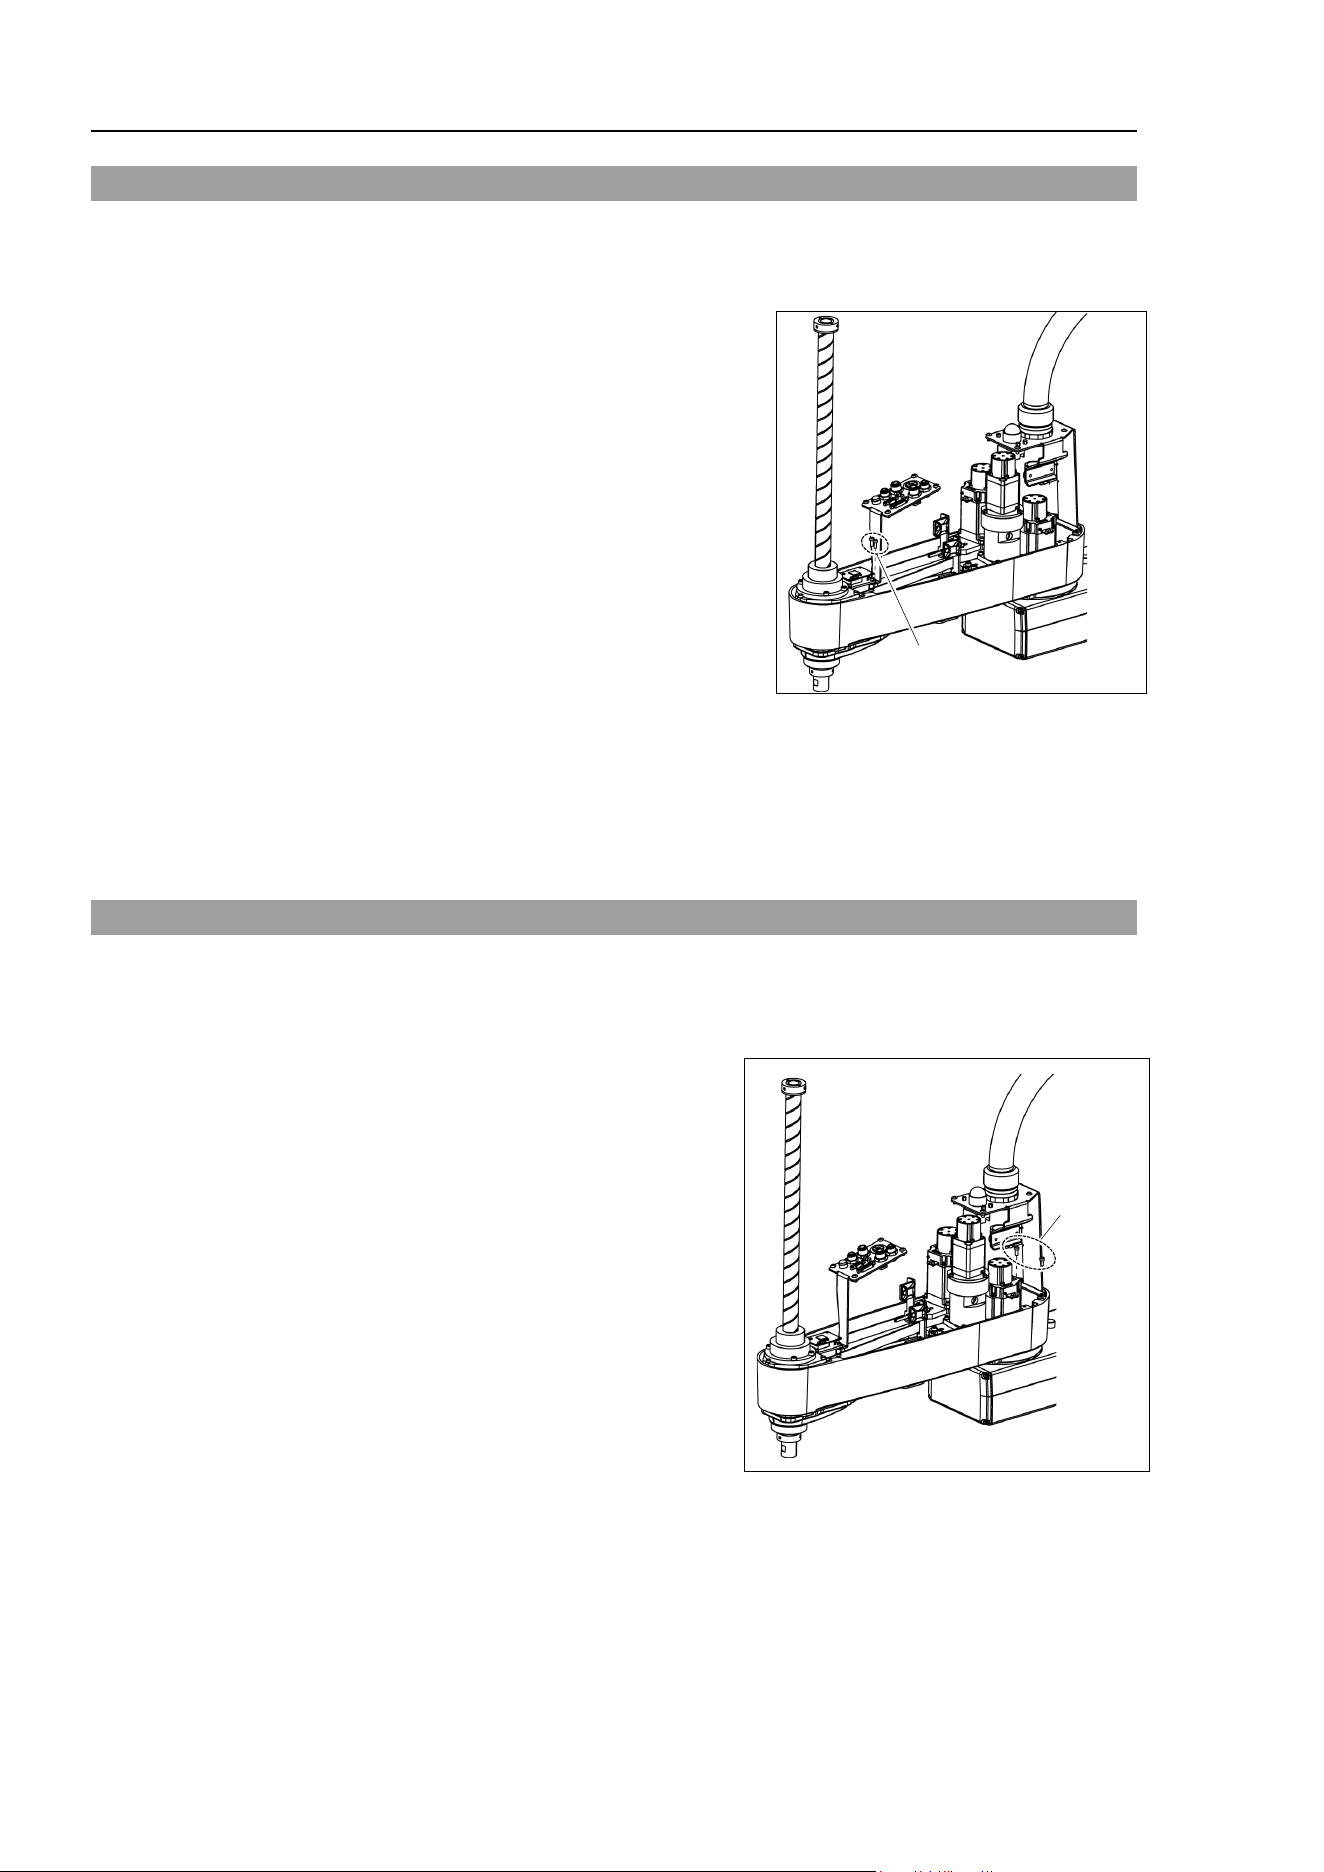
Maintenance 3. Covers
74
LS20-B R ev.4
3.6 User Plate
User Plate
Removal
(1)
Remove
the Arm Top Cover.
Refer to
Maintenance: 3.1 Arm Top Cover.
(2)
Unscrew the User Plate mounting bolts and
remove the plate.
2-M4×10
User Plate
Installation
(1)
Put the U
ser Plate to the arm and secure using the mounting bolts.
(2)
Mount the Arm Top Cover.
R
efer to Maintenance: 3.1 Arm Top Cover.
3.7 Duct Plate
D
uct Plate
Removal
(1)
Remove
the Arm Top Cover.
Refer to Maintenance: 3.1 Arm Top Cover.
(2)
Unscrew the Duct Plate mounting bolts and
remove the plate.
2-M4×10
Duct Plate
Installation
(1)
Put the Duct Plate to the arm and secure using
the mounting bolts.
(2)
Mount the Arm Top Cover.
R
efer to Maintenance: 3.1 Arm Top Cover.
Maintenance 4. Cable
LS20-B Rev.4 75
4. Cable
WARNING
■
Do not connect or disconnect the motor connectors while the power to the robot
system is turned ON. Connecting or disconnecting the motor connectors
with
the power ON is extremely hazardous and may result
in serious bodily injury as
the Manipulator may mo
ve abnormally, and also may result in electric shock
and/or malfunction of the robot system.
■
To shut off power
to the robot system, disconnect the power plug from the power
source. Be sure to connect the AC power cable to a power receptacle.
DO NOT connect it directly to a factory power source.
■
Before performing any replacement procedure, turn OFF the Controller and
related equipment,
and then disconnect the power plug from the power source.
Performing any replacement procedure with the power ON is extremely hazardous
and may result in
electric shock and/or malfunction of the robot system.
■
Be careful
not to get any foreign substances in the Manipulator, connectors, and
pins during maintenance.
Turning ON the power to the robot system when any
foreign substances exist in them is extremely
hazardous and may result in electric
shock
and/or malfunction of the robot system.
CAUTION
■
Be sure to connect the cables properly.
Do not allow unnecessary strain on the
cables. (Do not
put heavy objects on the cables. Do not bend or pull the cables
forcibl
y.) The unnecessary strain on the cables may result in damage to the
cables, disconnection, and/or contact failure. Damaged c
ables, disconnection,
or contact failure is extremely hazardous and may result in electric shock and/or
improper function of the robot system.
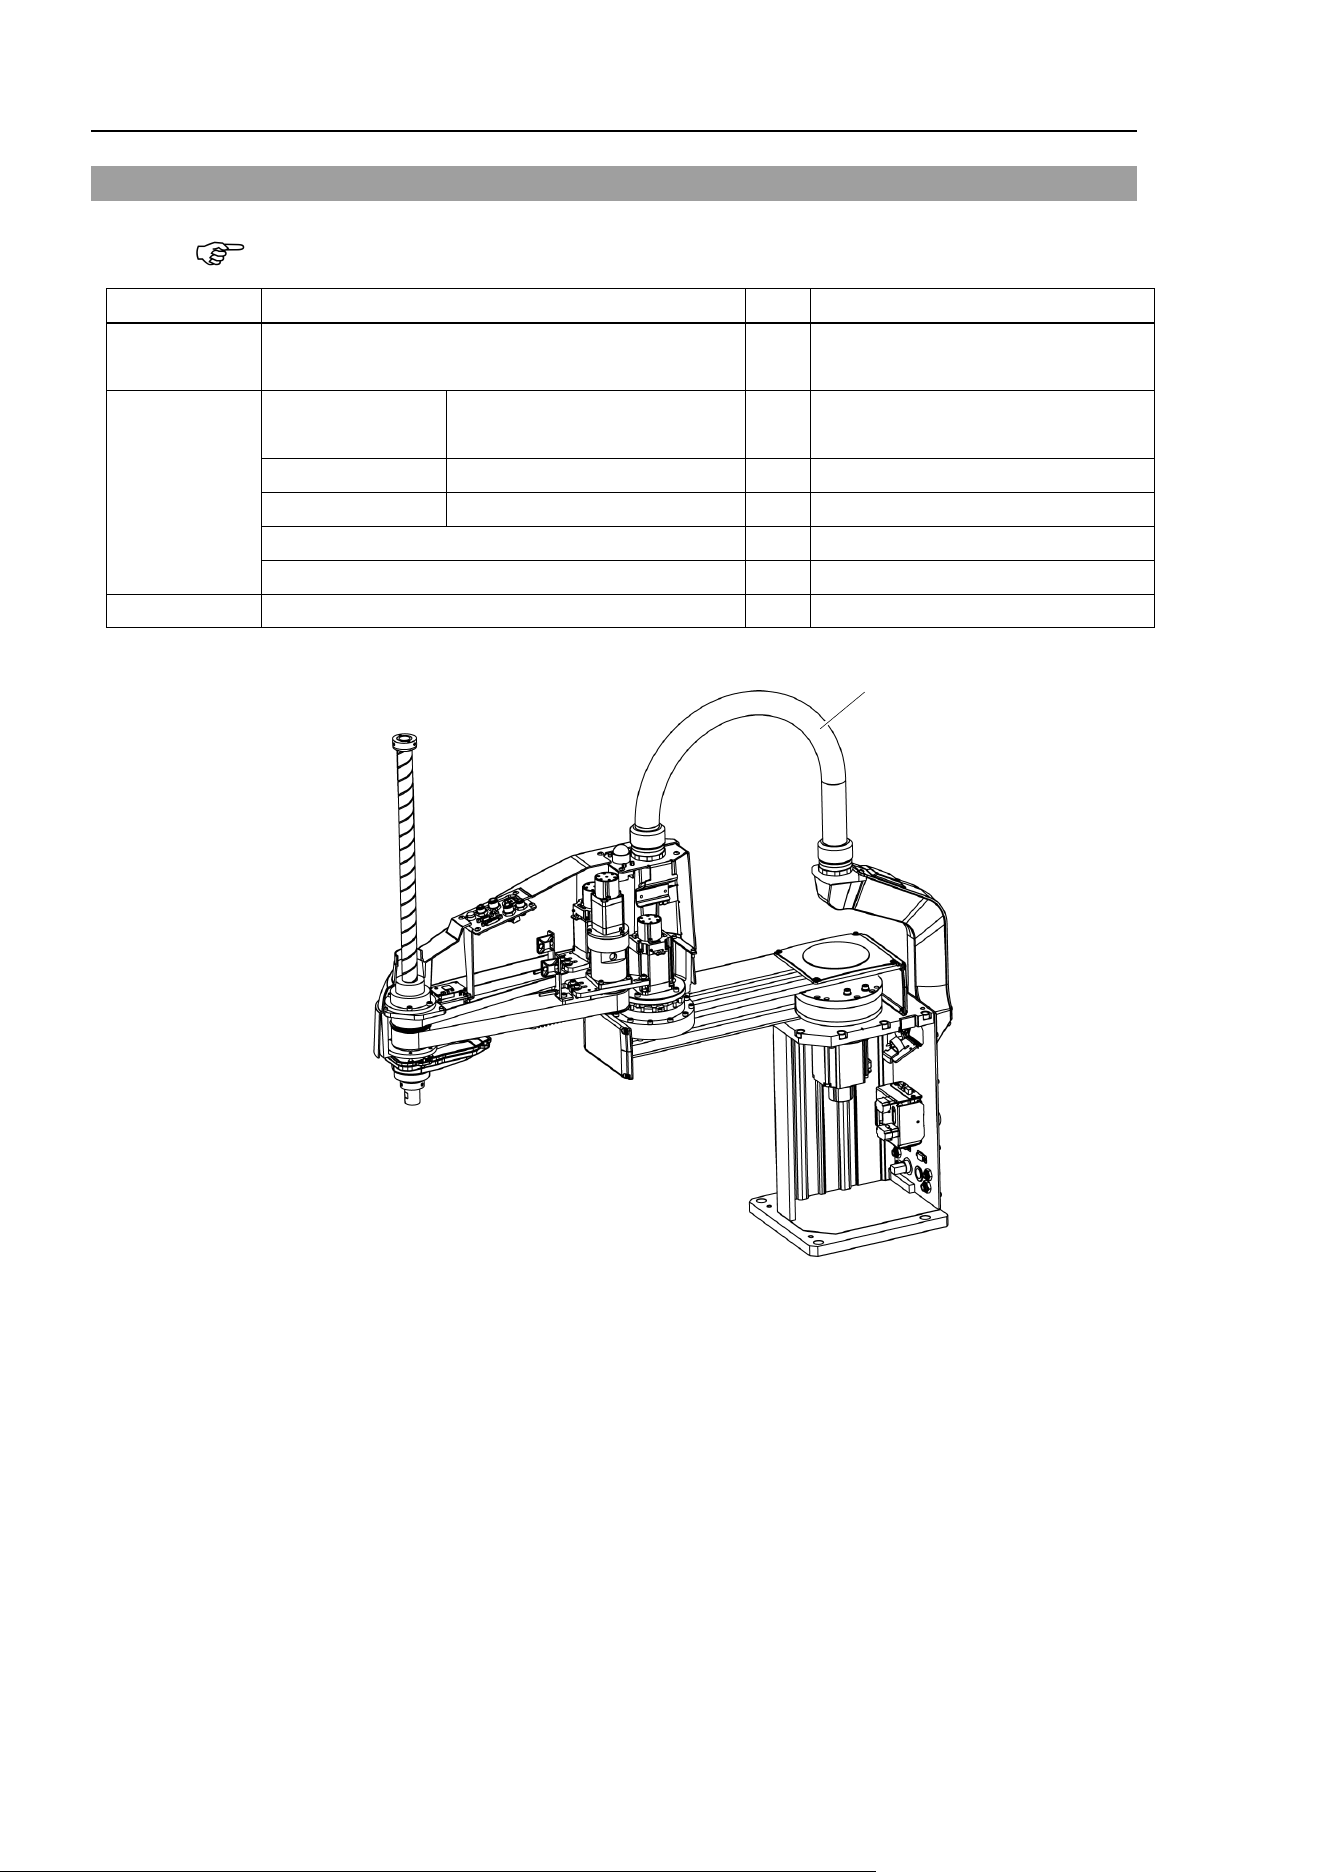
Maintenance 4. Cable
76
LS20-B R ev.4
4.1 Replacing Cable Unit
LS20-B series manipulator does not have batteries. Position data is memorized by the
motor. When replacing cables, calibration is not necessary.
Name
Qty.
Note
Maintenance
parts
Cable unit 1
LS20-B804*: 2202239
LS20-BA04*: 2202240
Tools
Hexagonal
wrench
width across flats: 3 mm 1 For M4 screw
Spanner
width across flats: 5 mm
1
For D-sub connector removal
Nut screwdriver
width across flats: 5 mm
1
For D-sub connector removal
Torque wrench
1
Nippers
1
For cutting wire tie
Material
Wire tie
-
Cable Unit
NOTE
Maintenance 4. Cable
LS20-B Rev.4 77
CAUTION
■
If the connectors have been disconnected during the replacement of the cable
unit, b
e sure to reconnect the following connectors to their proper positions
.
R
efer to the block diagrams. Improper connection of the connectors may result
in improper
function of the robot system. For details on the connections, refer to
Maintenance: 4.2 Wiring Diagrams.
■
When installing the cover, be careful not to allow the cables to interfere with the
c
over mounting and do not bend these cables forcibly to push them into the cover.
Unnecessary strain on cables may result in damage to the cables, disconnection,
and/or contact failure. Damaged cables, disconnection, or contact failure is
extremely hazard
ous and may result in electric shock and/or improper function of
the robot system.
When
routing the cables, observe the cable locations
after removing the cover.
Be sure to
place the cables back to their original locations.
■
Be sure to connect the cables properly. Do not allow unnecessary strain on the
cables. (Do not
put heavy objects on the cables. Do not bend or pull the cables
forcibl
y.) The unnecessary strain on the cables may result in damage to the
cables, disconnection, and/or contact fai
lure. Damaged cables, disconnection,
or contact failure is extremely hazardous and may result in electric shock and/or
improper function of the robot system.
A brake is mounted on the motor of Joints #3 and #4 to prevent the shaft from moving down
and rotating due to the weight of the end effector while the power to the Controller is OFF
or while the motor is in OFF status (MOTOR OFF).
Move the shaft down to its lower limit before the replacement procedure following the
removal steps.
Cable Unit
Removal
(1)
Turn ON the Controller and change the motor to OFF status (MOTOR OFF).
(2)
Press and hold
the brake release switch to let the shaft down. Be sure to keep enough
space and prevent the
end effector hitting any peripheral equipment.
The brake release switch is applied to both Joints #3 and Joint #4.
When the brake release switch is pressed, the respective brakes of the Joint #3 and Joint
#4 are
released simultaneously.
Be careful of the
shaft falling and rotating while the brake release switch is
being
pressed
because the shaft may be lowered by the weight of an end effector.
(3)
Turn OFF
the Controller.
(4)
Remove the Connector Sub
Plate from the Connector Plate.
For details, refer to Maintenance 3.5 Connector Sub Plate
(5)
Disconnect M/C cable.
For details, refer to Setup & Operation 3.6 Connecting the Cables - Connect and
disconnect M/C cable.
(6)
Remove the
Connector Plate.
For details, refer to Maintenance: 3.4 Connector Plate.
NOTE
NOTE
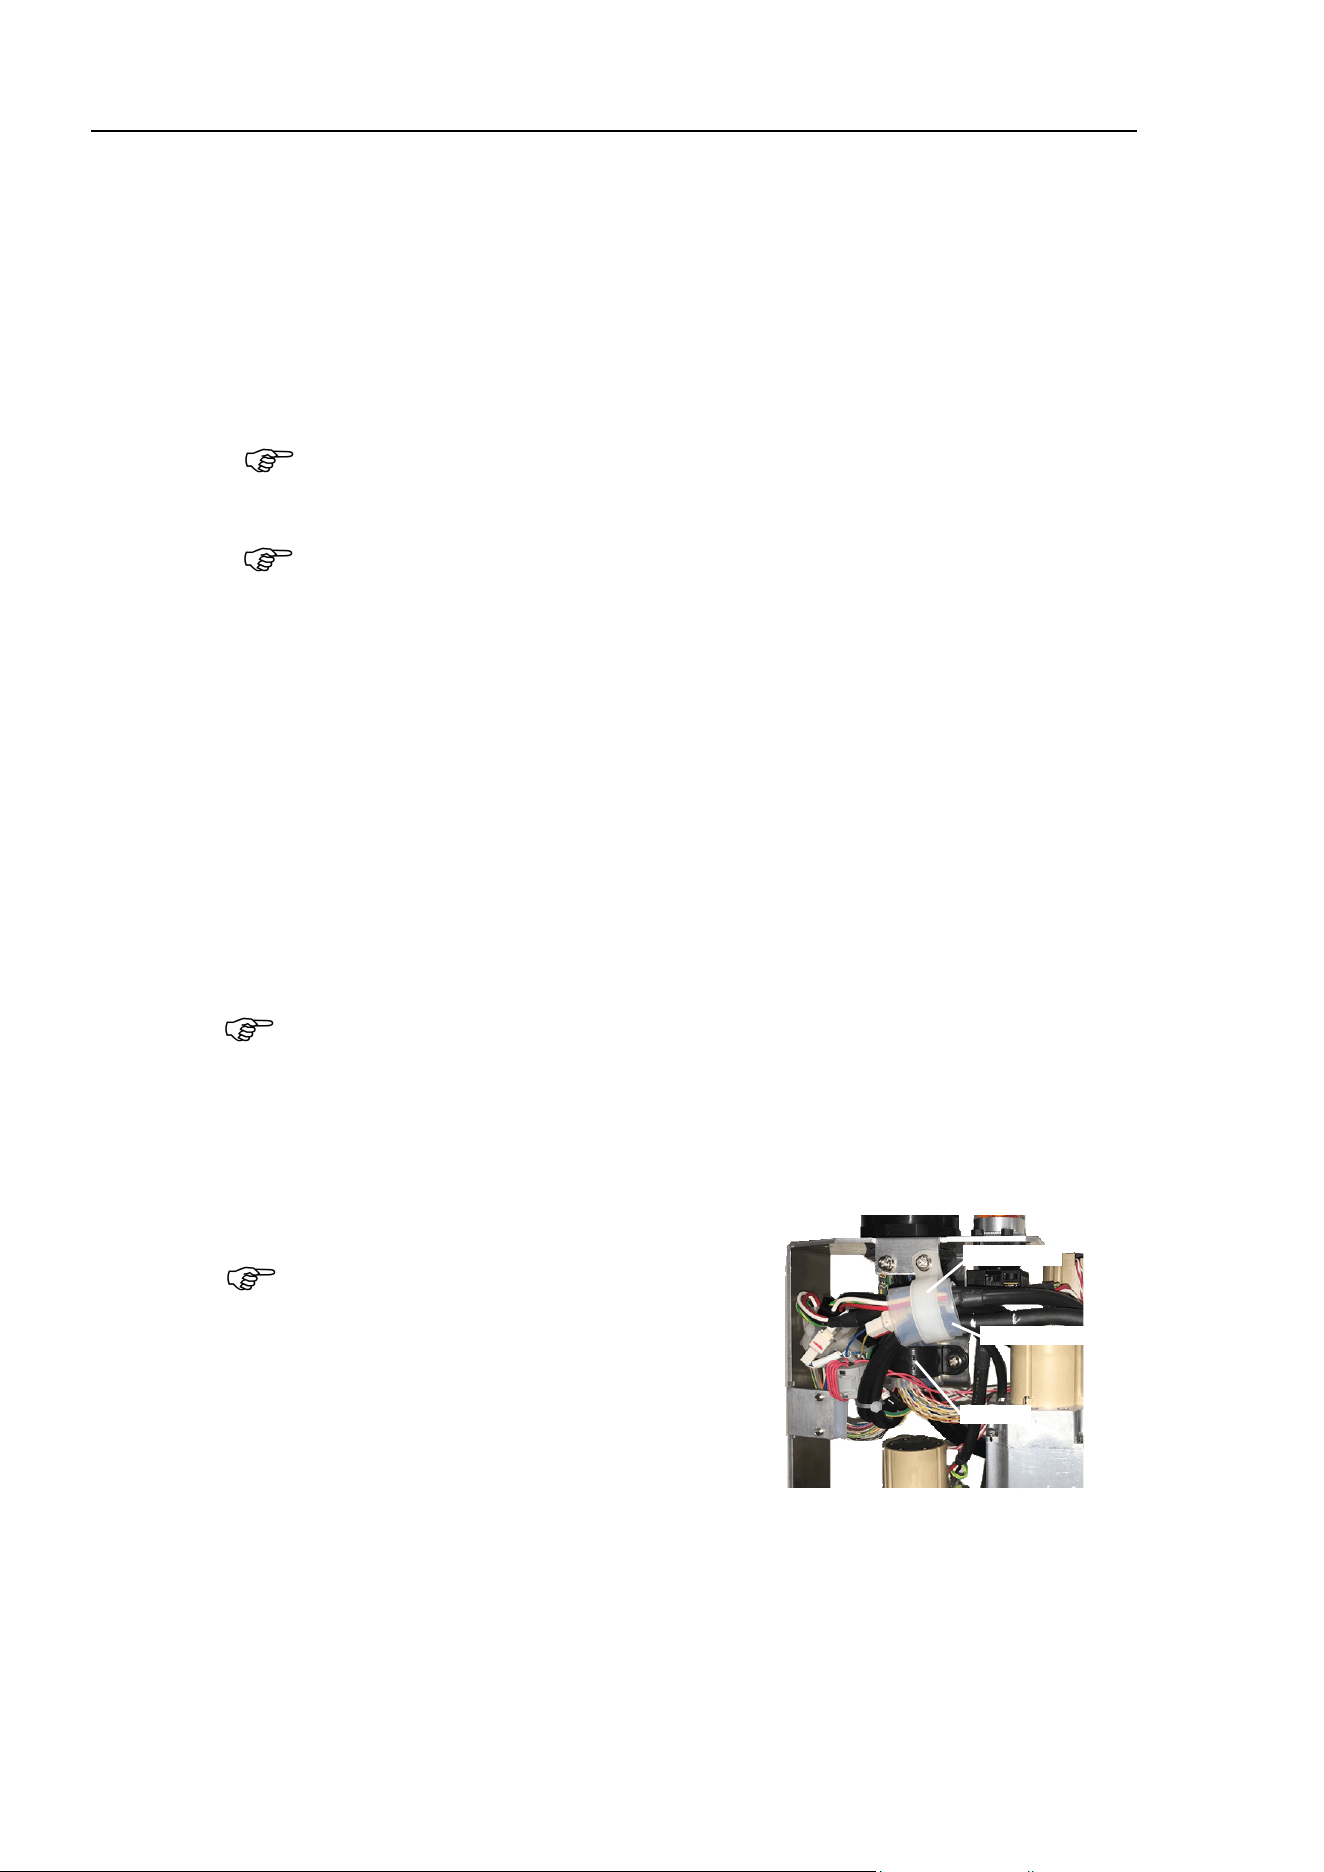
Maintenance 4. Cable
78
LS20-B R ev.4
(7)
Remove the following that connected to the (inside) of
the Connector Plate and
Connector Sub Plate.
P
neumatic tube
D-sub cable
Ethernet cable (RJ45)
Connectors: X11, X111, X121, CV11, CV12, CV13
F
or connectors fixed on the mount base, disconnect by holding the clip.
Be careful not to lose the spacer which holding the
ground wires.
(8)
Cut off the two wire ties binding the cables on the base
side cable fixing plate.
Remember the cable layout for reconnecting the disconnected parts after replacement.
(9)
Disconnect
two connectors inside the Base.
Connectors: X41, X211
(10)
Remove
the Arm Top Cover.
For details, refer to Maintenance: 3.1 Arm Top Cover.
(11)
Remove the User Plate.
F
or details, refer to Maintenance: 3.6 User Plate.
(12)
Disconnect 11 connectors on the Arm side.
C
onnectors: X22, X33,X42, X43, X44, X51, BR3, BR4, X221, X231, X241
(13)
Disconnect the D
-sub cable, pneumatic tube, and Ethernet cable (RJ45) from the User
Plate.
Mounting screws for the D
-sub cable are very small. Be sure to keep the screws.
Press the ring on the fittings to pull out the
pneumatic tube. (ø6×2, ø8×1)
Remember
the cable layout for reconnecting the disconnected parts after replacement.
(14)
Remove the two ground wires
from Joint #3 Plate and Duct Plate.
(15)
Cut off the wire tie binding the cables in the
Arm side.
Remove the following parts
:
Clip band, saddle
Removed parts will be used again.
Be careful not to lose them.
Cables are wrapped in a silicon sheet for
protection.
The sheet will be reused when
installing the cable unit
.
Be careful not to lose it.
Arm #2 side
Saddle
Silicone Sheet
Clip Band
NOTE
NOTE
NOTE
NOTE
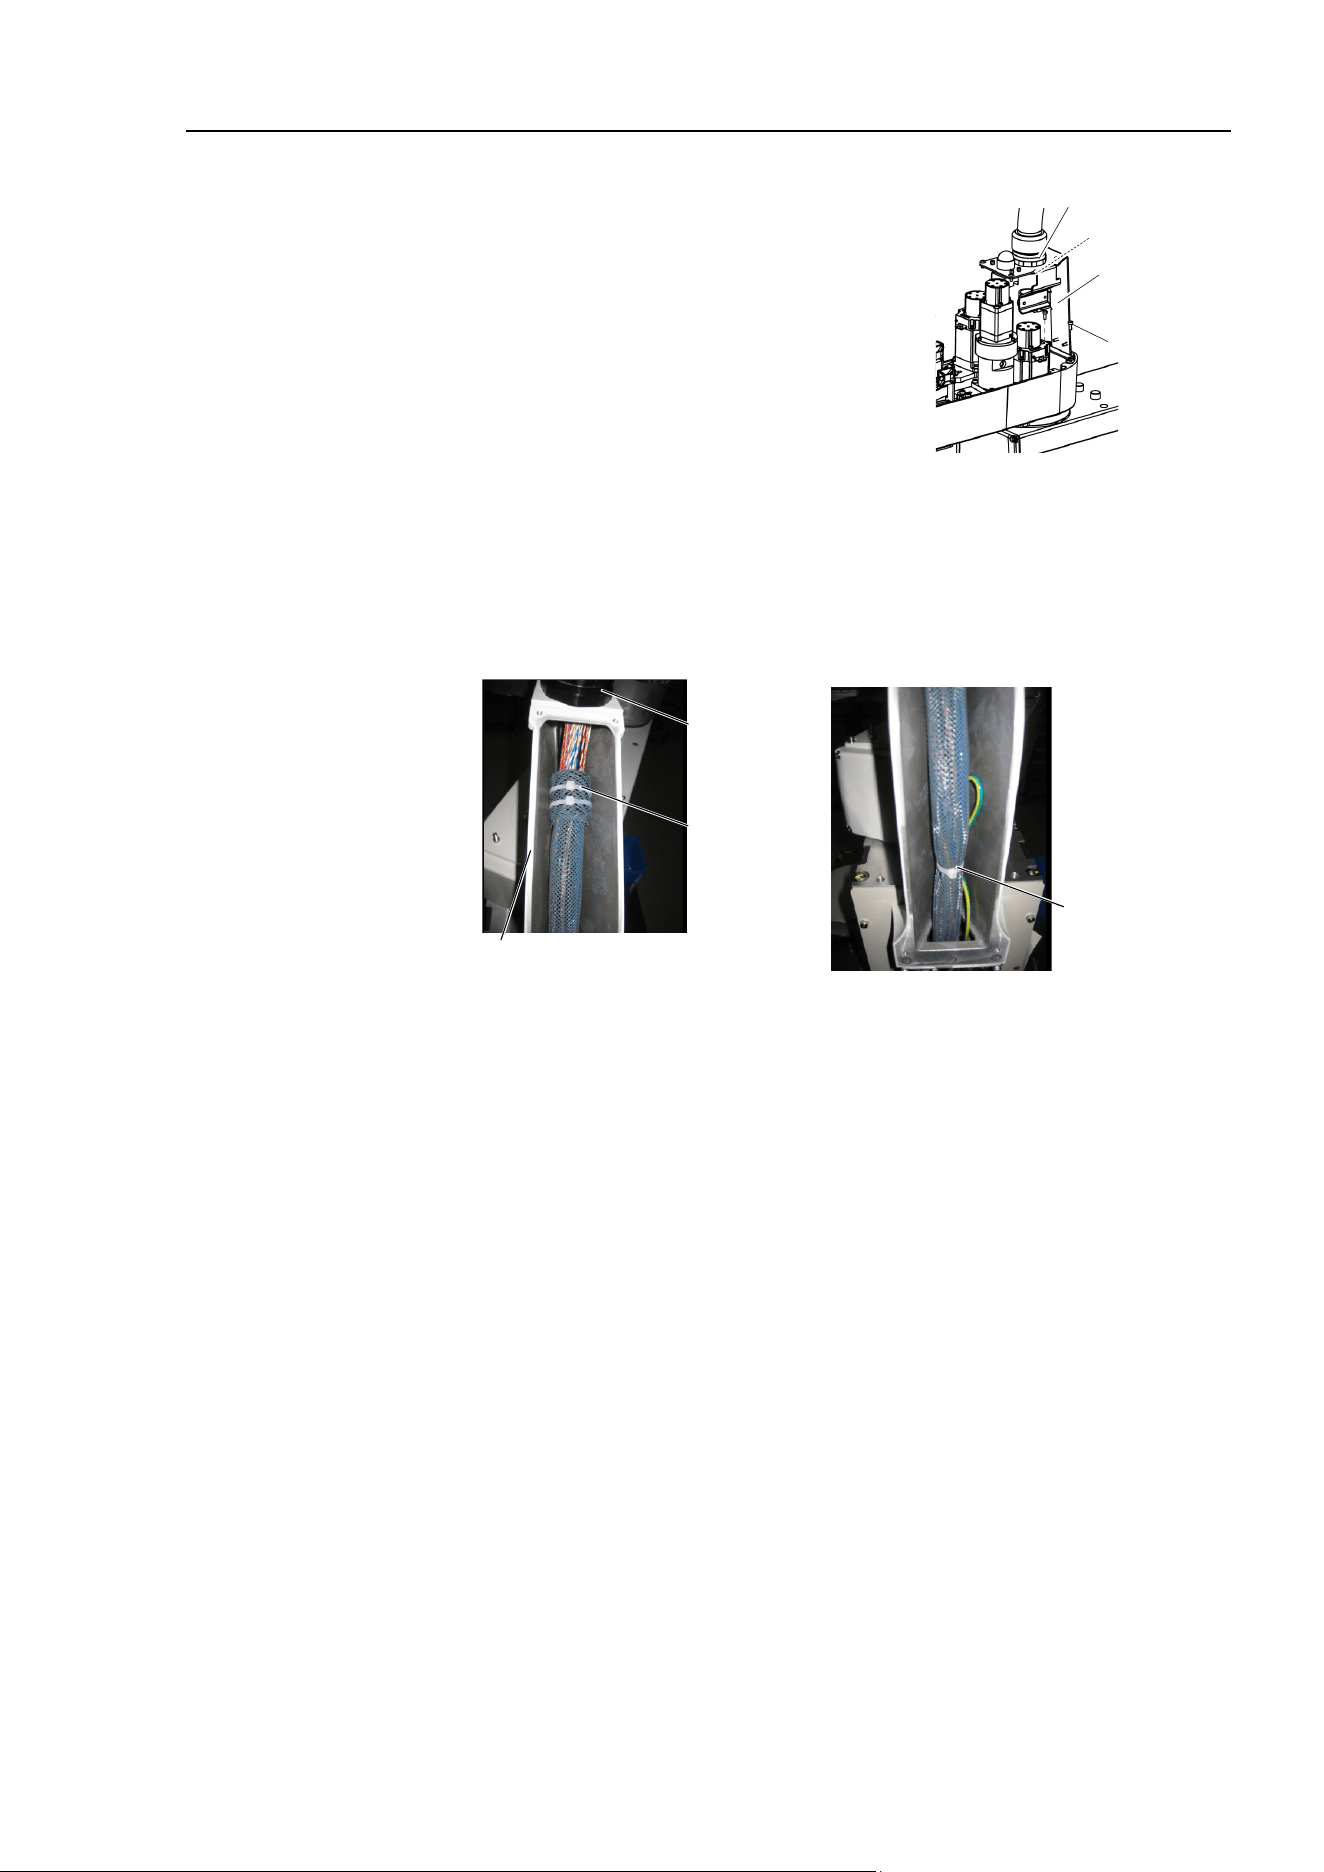
Maintenance 4. Cable
LS20-B Rev.4 79
(16)
Remove the nut of the rotary
fitting.
Remove the rotary
fitting from the Duct Plate.
Disconnect the cables from the
Duct Plate.
Nut
2-M4×10
Rotary Fittings
Duct Plate
(17)
Remove the rotary fitting from the metal duct.
The rotary fitting is directly screwed in the metal duct.
Loosen the screws to remove
the fitting.
Cut off the wire tie fixing the cables, and then disconnect the
cables from the metal
duct.
Metal duct
Rotary fitting
Wire tie
Wire tie
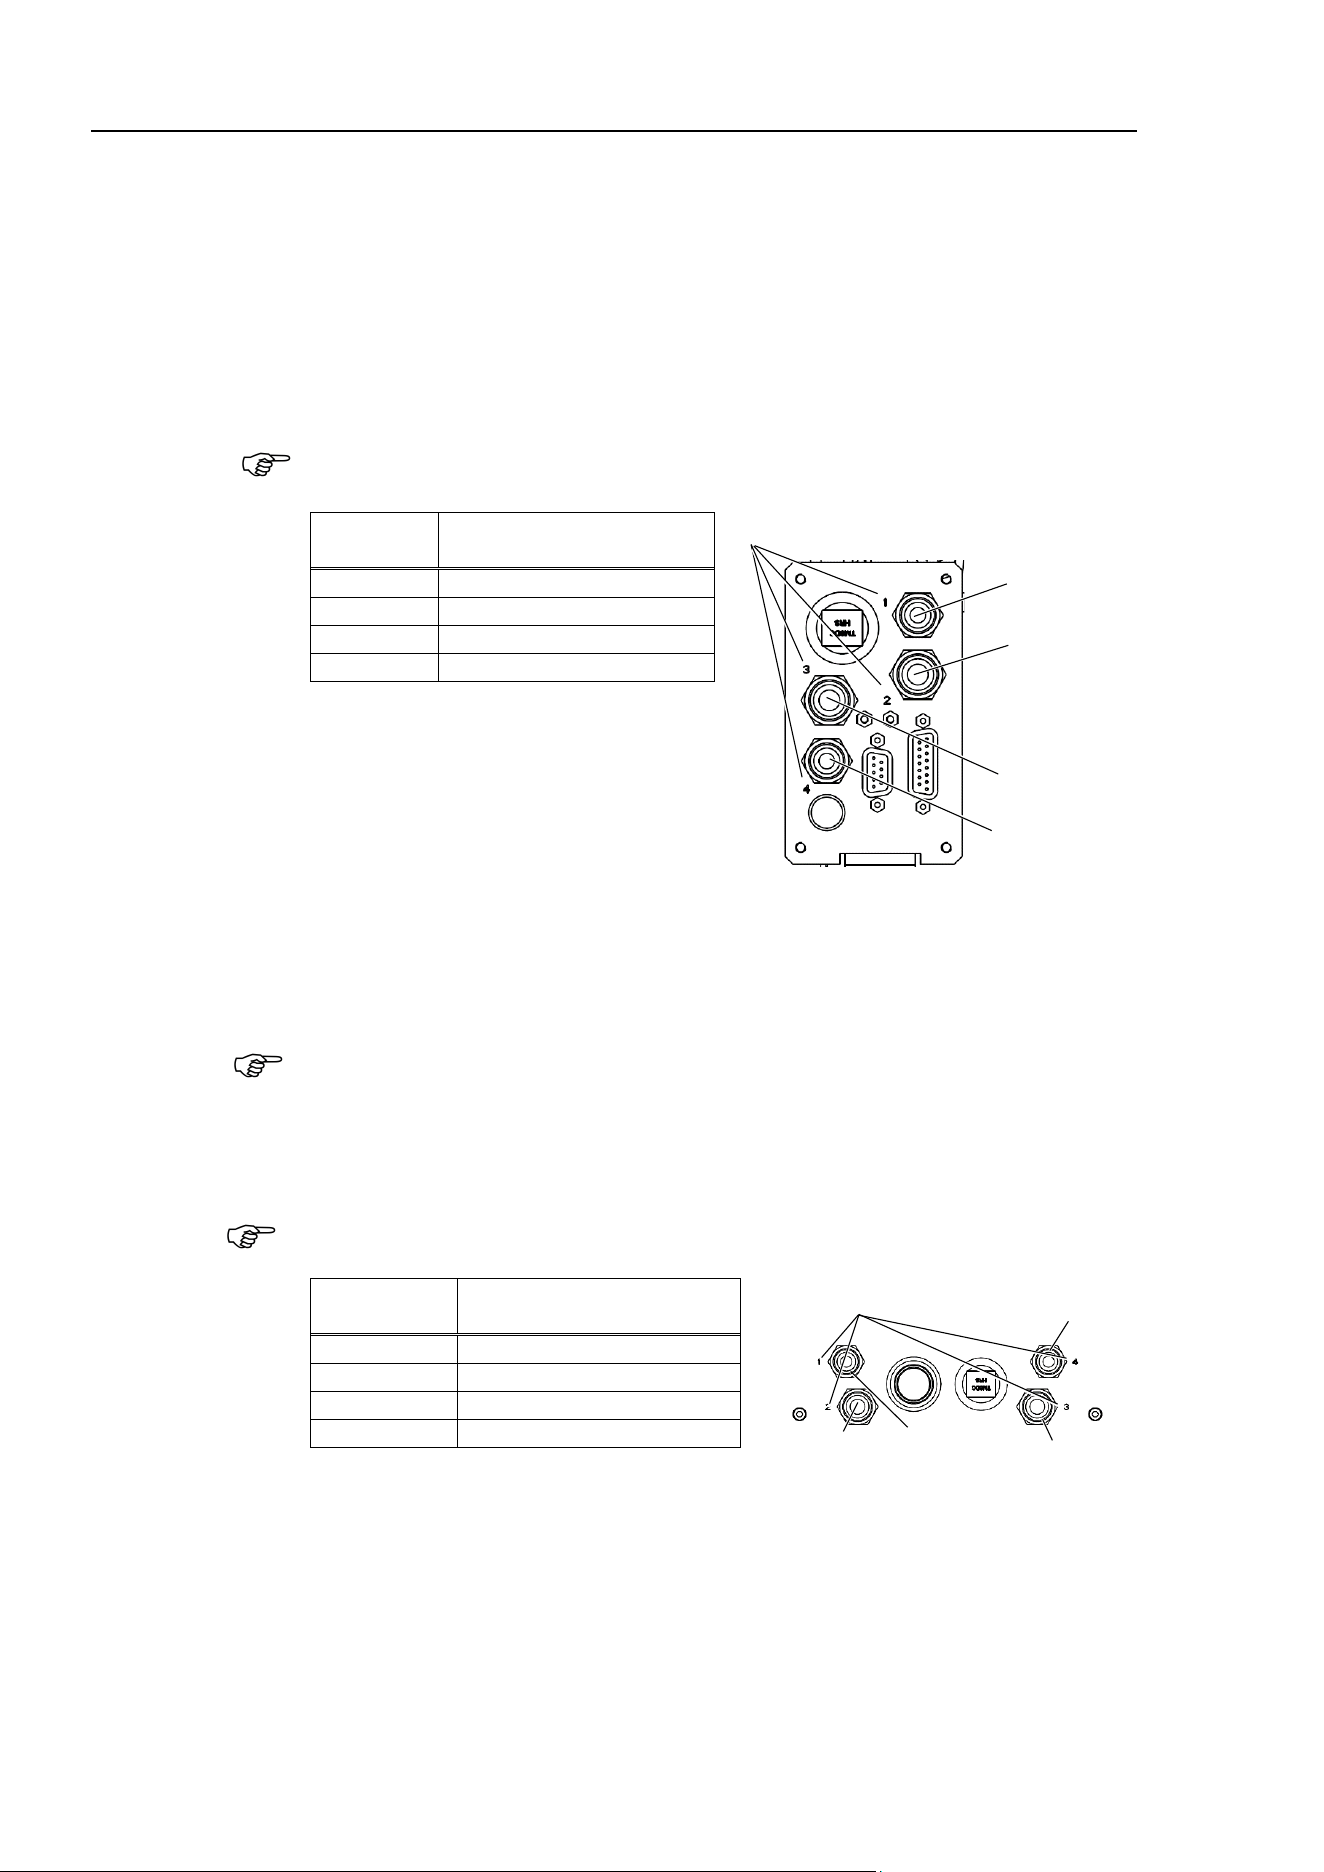
Maintenance 4. Cable
80
LS20-B R ev.4
Cable Unit
Installation
(1)
Pass the new cables through the Cable Duct Unit. Then, rotate the fittings to secure the
cables.
(2)
Pass the cables in the Duct Plate side through the Duct Plate and nut and turn the fittings
to secure the cables.
(3)
Connect the following
parts to the Connector Plate.
Pneumatic tube, D-sub cable, Ethernet cable (RJ45), ground wire (×7)
All fittings of LS20
-B series manipulators are white. See the
table below for connection
of pneumatic tube to fittings.
Fitting
No.
Pneumatic tube
(Color / Outer Diameter)
1
Blue / ø6
2
Blue / ø8
3
Black / ø8
4
Black / ø6
Fitting No.
Blue: ø6
Black: ø8
Blue: ø8
Black: ø6
(4)
Connect two connectors on t
he Base side.
Connectors: X41, X211
(5)
B
ind the cables with a new wire tie as before in the removal step (8).
Fix the short flexible tube shipped with the cable unit with the wire tie at the upper side
of the metal duct.
(6)
Connect the following
parts to the User Plate.
Pneumatic tube, D-sub cable, Ethernet cable (RJ45)
All fittings of LS20
-B series manipulators are white. See the
table below for connection
of pneumatic tube to fitting
s.
Fitting No.
Pneumatic tube
(Color / Outer Diameter)
1
Blue / ø6
2
Blue / ø8
3
Black / ø8
4
Black / ø6
Blue: ø8
Fitting No.
Blue: ø6
Black: ø8
Black: ø6
(7)
Mount the User Plate.
F
or the details, refer to Maintenance: 3.6 User Plate.
(8)
Connect the
following connectors.
Connectors: X22, X33,X42, X43, X44, X51, BR3, BR4, X221, X231, X241
(9)
Mount
two ground wires in the Arm side to the Joint #3 Motor Plate and Duct Plate.
NOTE
NOTE
NOTE
Maintenance 4. Cable
LS20-B Rev.4 81
(10)
As with the wire tie cut off at the removal step (14), bind
the cables with a new wire tie.
Wrap the cables in the silicon sheet for protection.
Bind the cables with the clip
band and the saddle.
(11)
Mount the Connector Plate.
For the details, refer to Maintenance: 3.4 Connector Plate.
(12)
Place and secure the Arm Top Cover without the cables being stuck.
For details, refer to Maintenance: 3.1 Arm Top Cover.
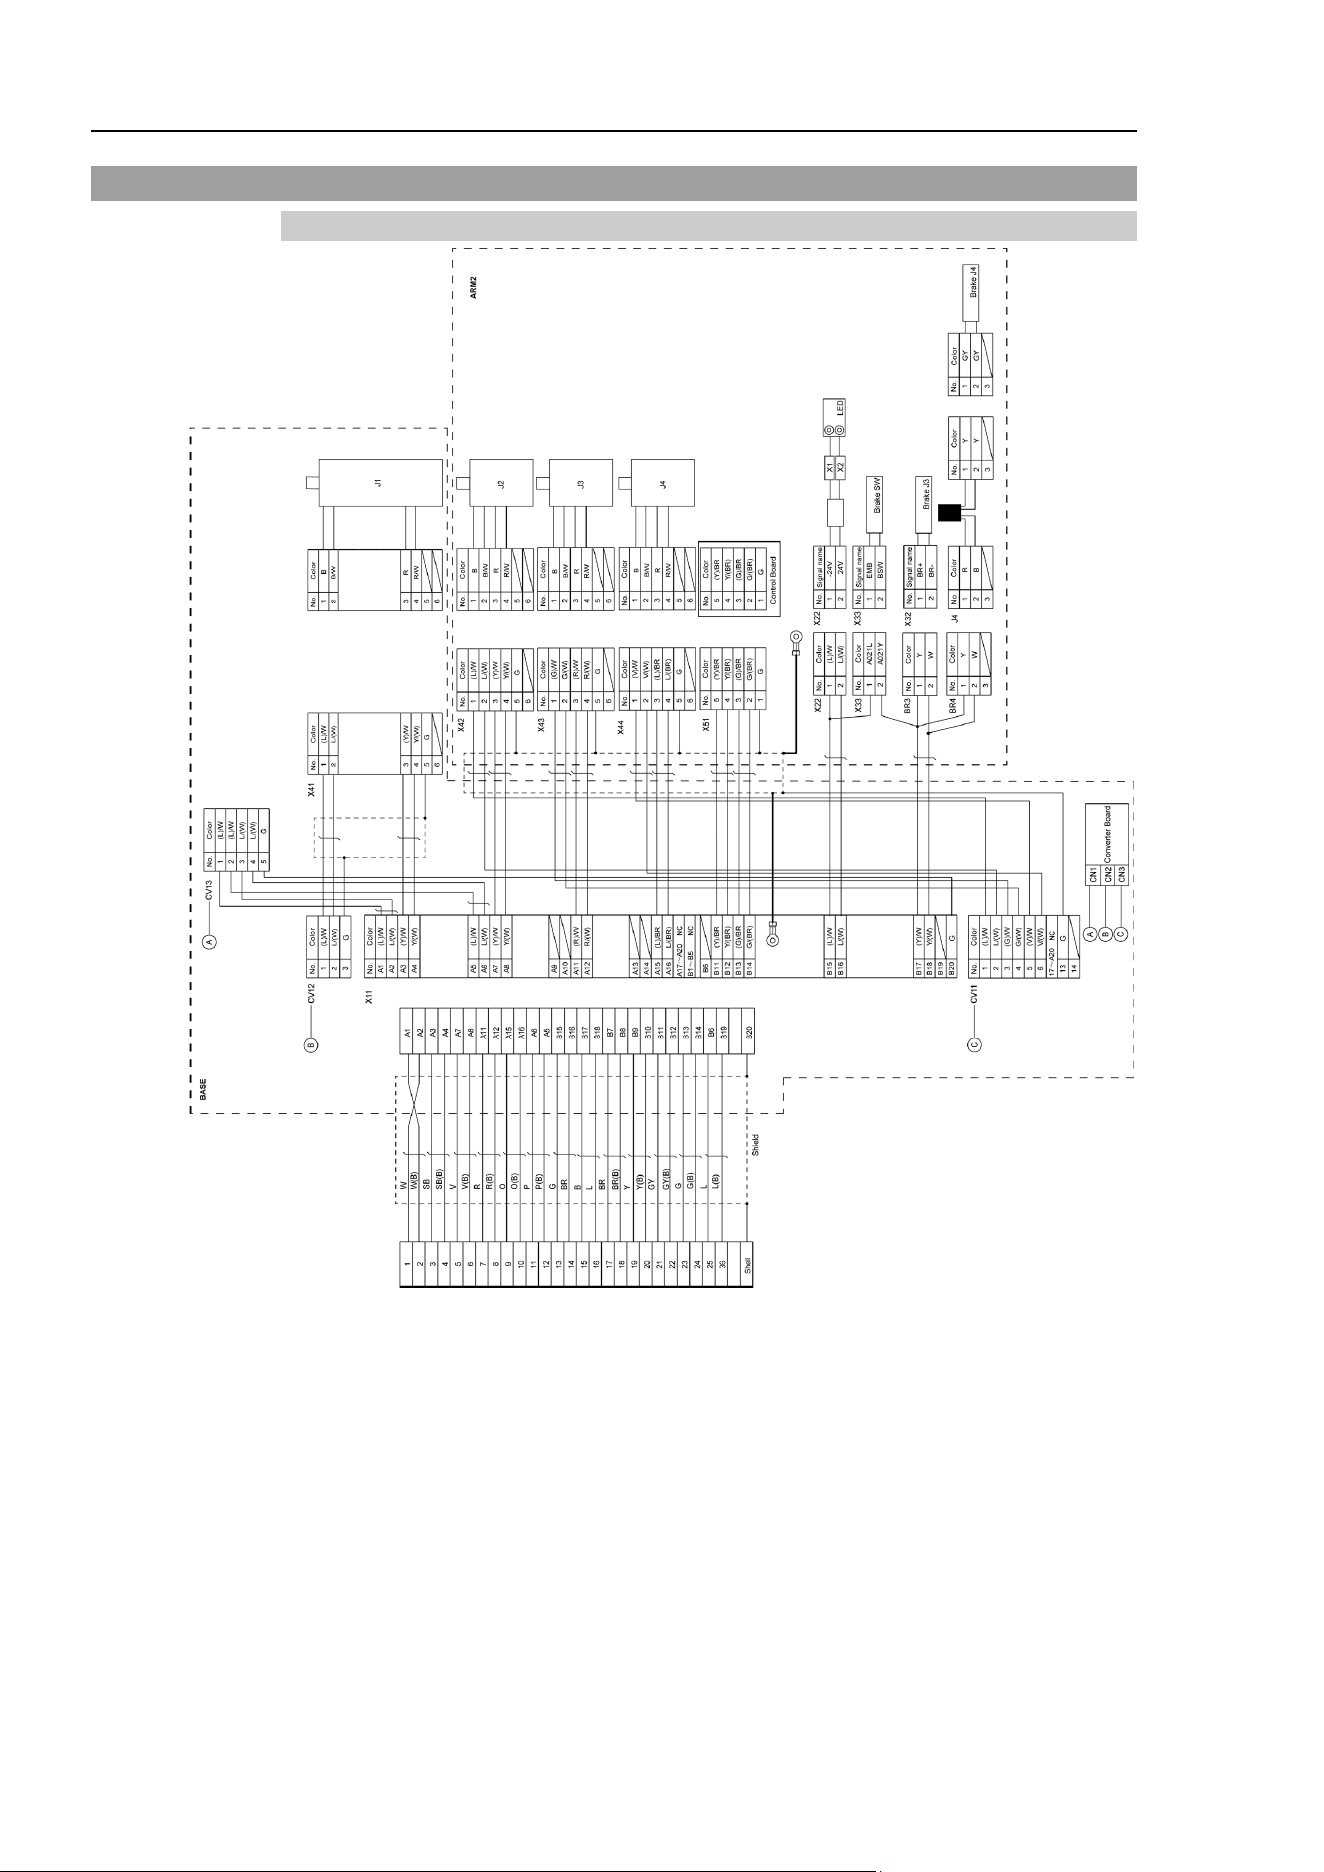
Maintenance 4. Cable
82
LS20-B R ev.4
4.2 Wiring Diagrams
4.2.1 Signal Cable
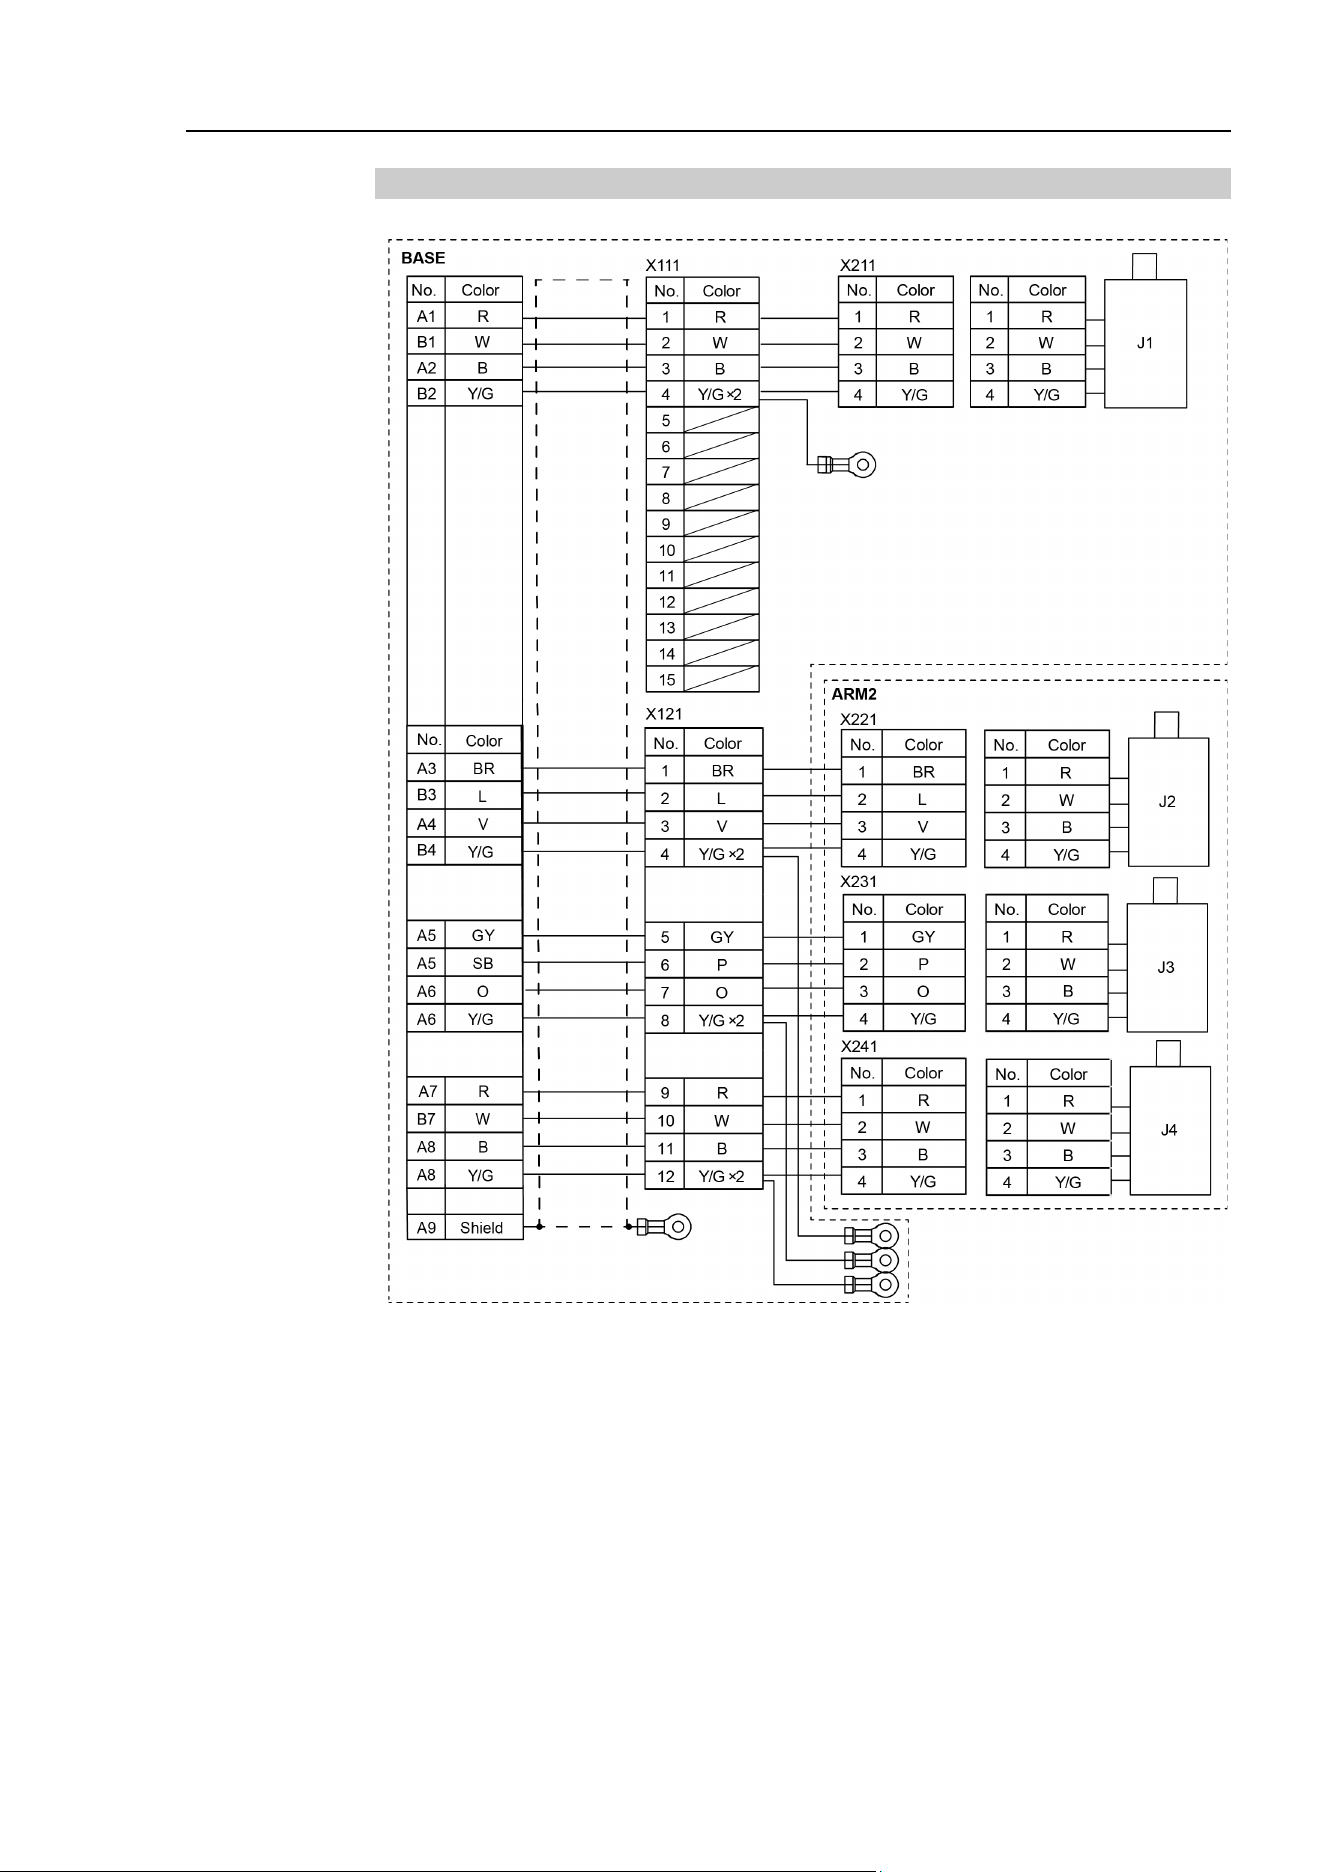
Maintenance 4. Cable
LS20-B Rev.4 83
4.2.2 Power Cable
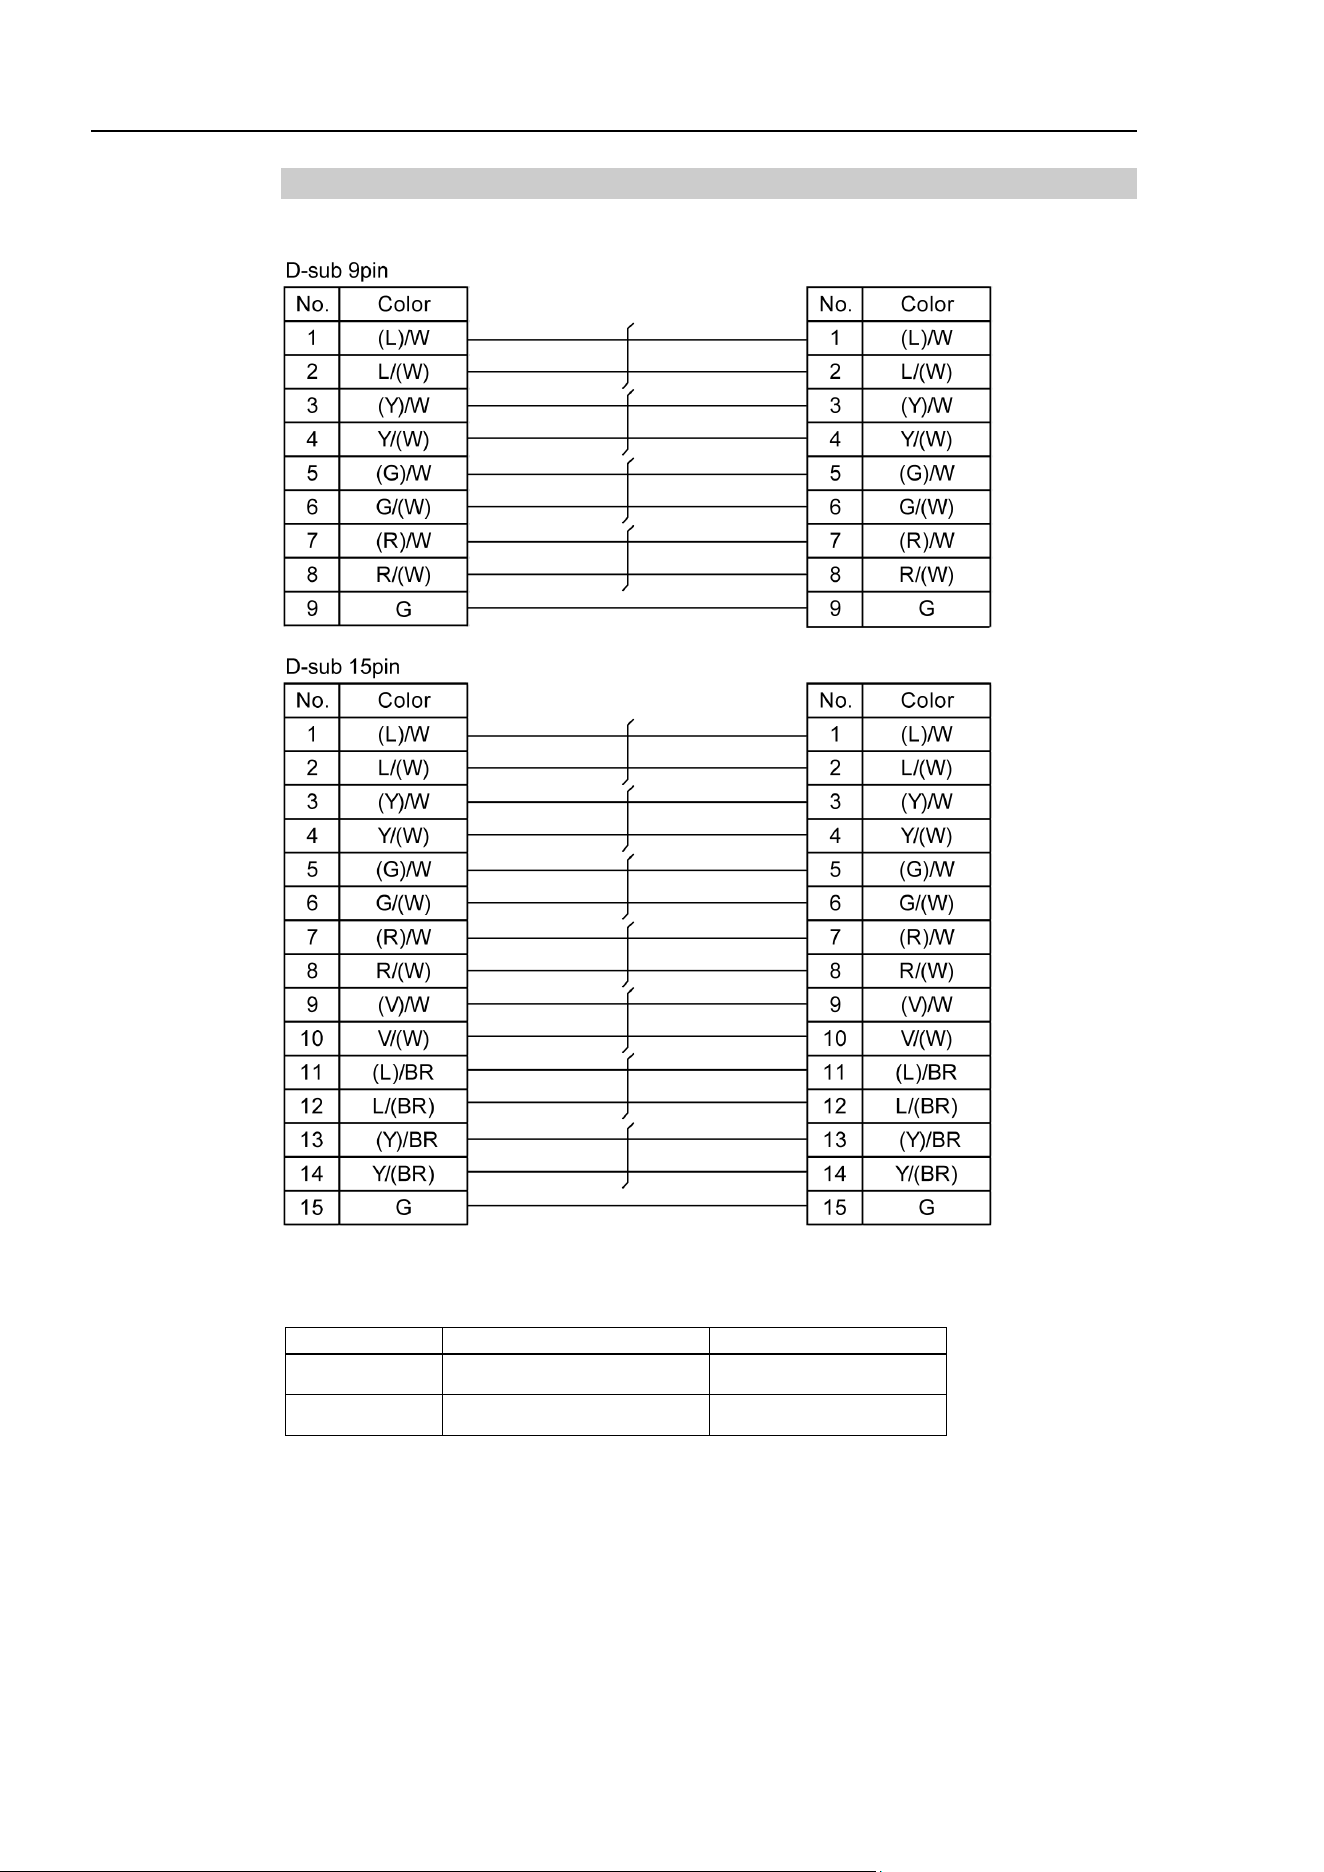
Maintenance 4. Cable
84
LS20-B R ev.4
4.2.3 User Cable
The following table shows the types of User cable.
Model name
Model type
Code
LS20-B804*
Standard, Cleanroom 2202239
LS20-BA04*
Standard, Cleanroom 2202240
Maintenance 4. Cable
LS20-B Rev.4 85
4.2.4 Color of Cables
The following table shows the codes and cable colors indicated in the pin assignments.
4.2.1 Signal Cable
4.2.2 Power Cable
4.2.3 User Cable
Code
Cable color
B
Black
W
White
R
Red
G
Green
Y
Yellow
BR
Brown
L
Blue
V
Violet
O
Orange
P
Pink
SB
Sky blue
GY
Gray
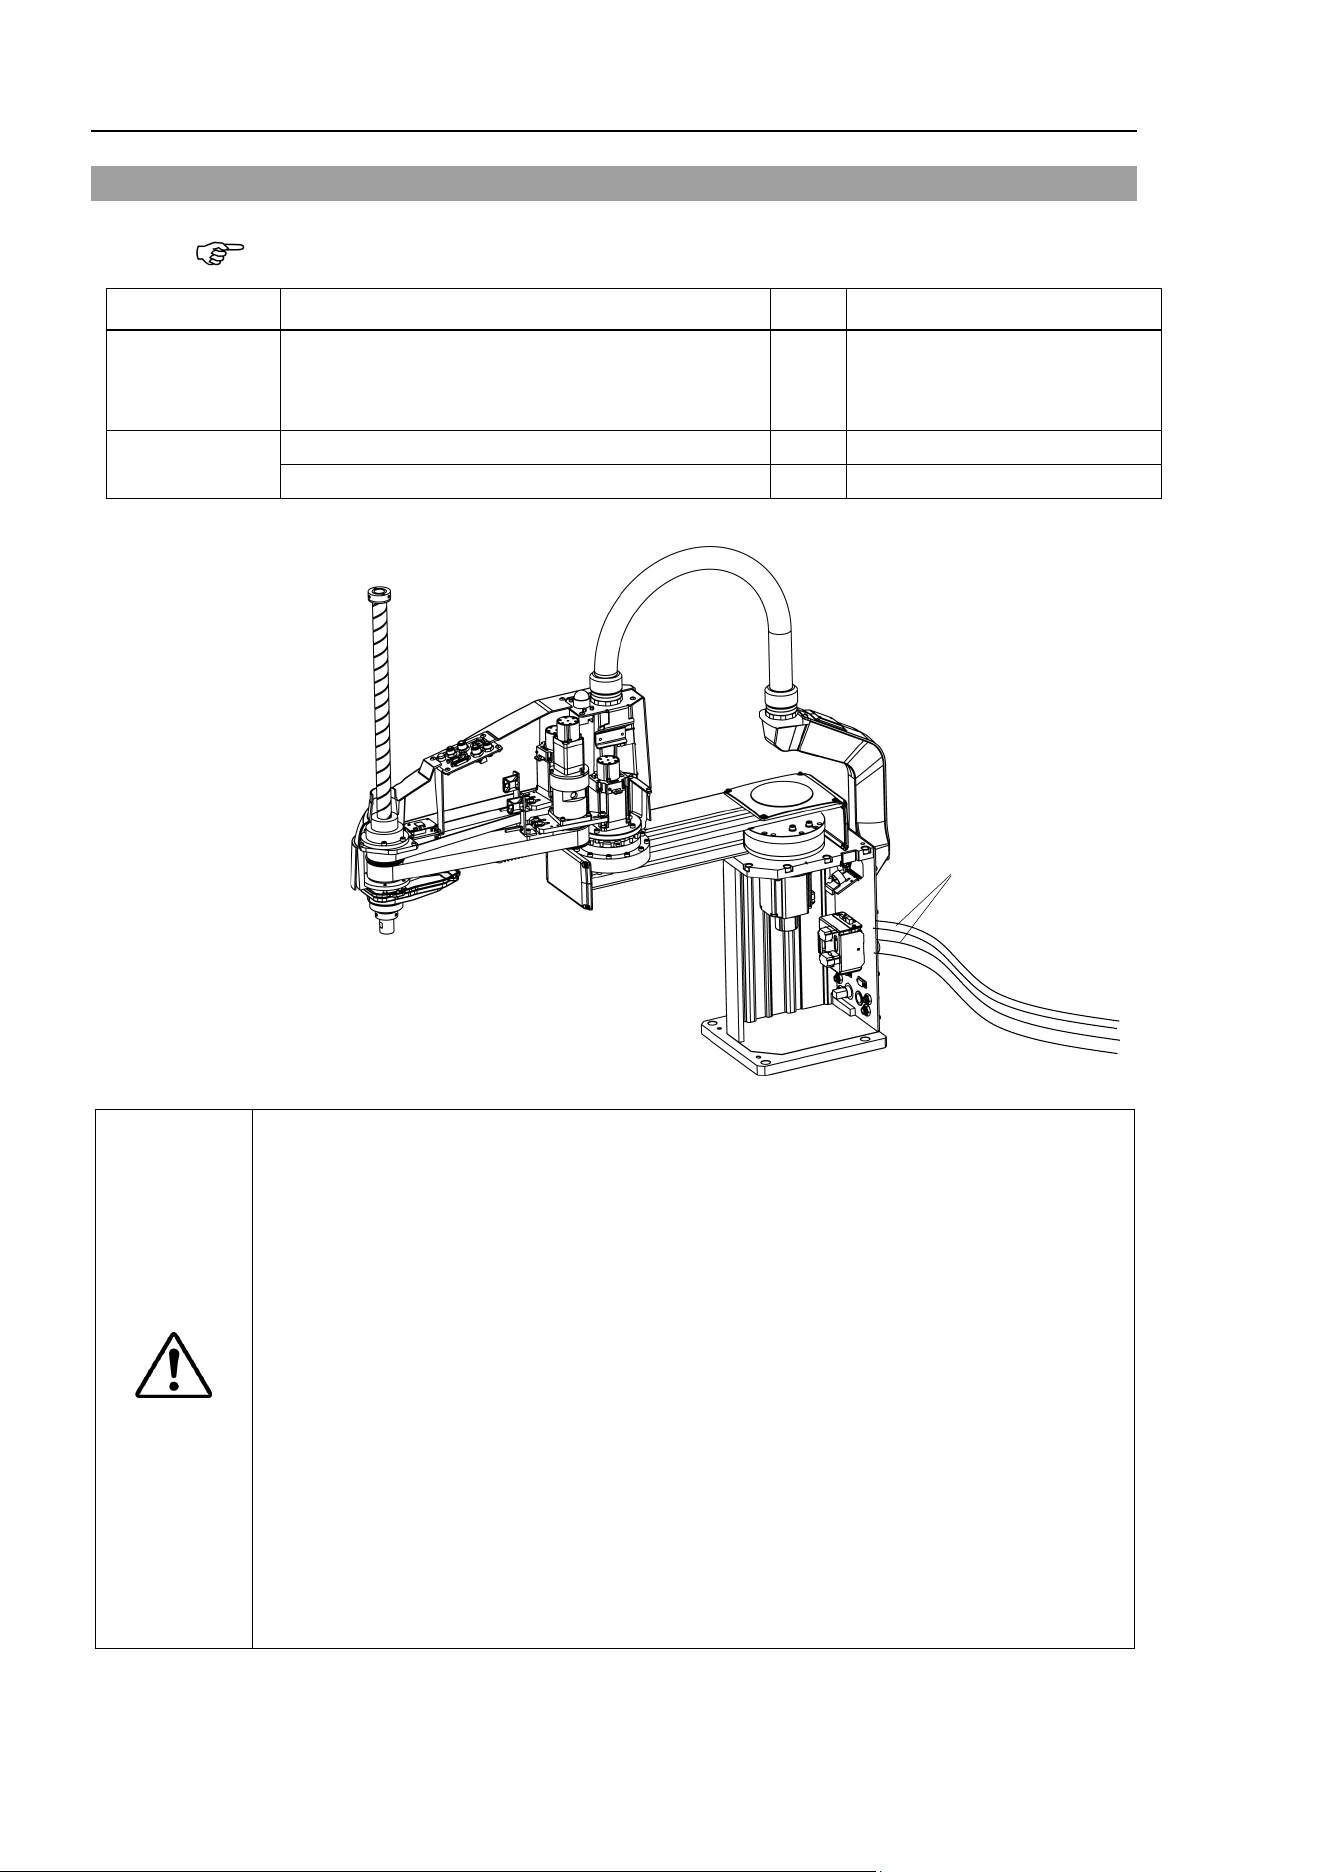
Maintenance 4. Cable
86
LS20-B R ev.4
4.3 Replacing M/C Cable
LS20-B series manipulator does not have batteries. Position data is memorized by the
motor. When replacing cables, calibration is not necessary.
Name
Qty.
Note
Maintenance
part
M/C Cable 1
3 m: 2196934
5 m: 2196935
10 m: 2196936
Tool
Flathead screwdriver
1
Torque wrench
1
M/C cable
C
AUTION
■
If the connectors have been disconnected during the replacement of the cable
unit, b
e sure to reconnect the following connectors to their proper positions
.
R
efer to the block diagrams. Improper connection of the connectors may result
in improper
function of the robot system.
For details on the connections, refer to
Maintenance: 4.2 Wiring Diagrams.
■
When installing the cover, be careful not to allow the cables to interfere with the
cover mounting and do
not bend these cables forcibly to push them into the cover.
Unnecessary strain on cables may result in damage to the cables, disconnection,
and/or contact f
ailure. Damaged cables, disconnection, or contact failure is
extremely hazardous and may result in electric shock and/or improper function of
the robot system.
When
routing the cables, observe the cable locations
after removing the cover.
Be sure to
place the cables back to their original locations.
■
Be sure to connect the cables properly. Do not allow unnecessary strain on the
cables. (Do not
put heavy objects on the cables. Do not bend or pull the cables
forcibl
y.) The unnecessary strain on the cables may result in damage to the
cables, disconnection, and/or contact failure. Damaged cables, disconnection,
or contact failure is extremely hazardous and may result in electric shock and/or
improper function of the robot system.
NOTE
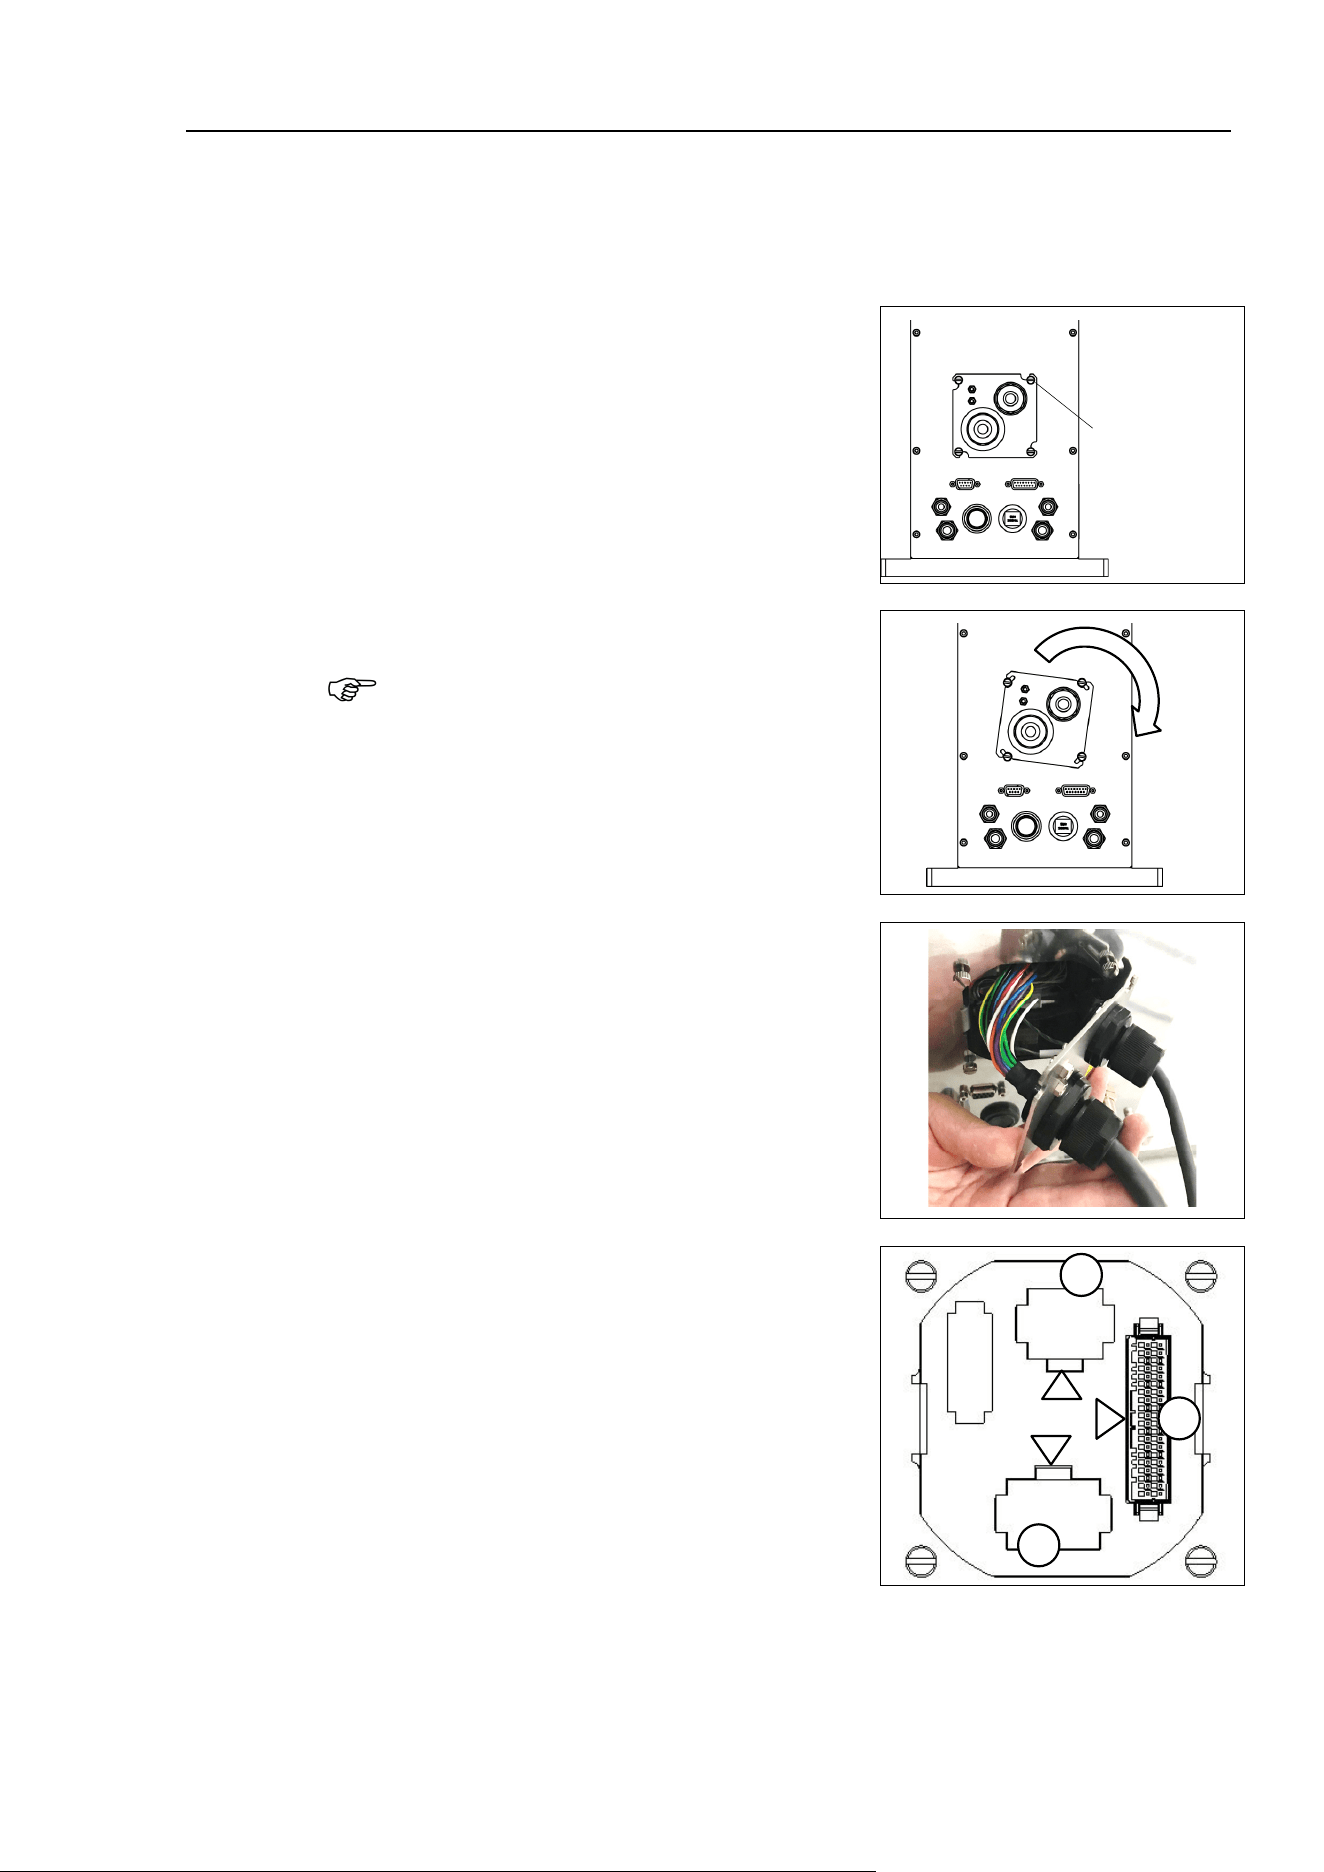
Maintenance 4. Cable
LS20-B Rev.4 87
M/C Cable
Removal
(1)
Turn OFF
the Controller.
(2)
Disconnect the following connectors form the controller.
Power cable connector Signal cable connector
(3)
Loosen the screws fixing the plate.
You do not need to remove them
completely.
For details, refer to
Maintenance: 3.3 Connector Plate.
Finger Screws
(4)
Slide the plate to remove it from the base.
Do not pull the M/C cable after removing
the
plate.
M/C cables are connected by the
connectors.
Doing so may result in
disconnection of the cables.
(5)
As shown on the right, pull out the cables from
the Manipulator.
(6)
Dis
connect the following connectors
in the
order as shown on the right.
C
lips of the connectors are △
positions in
the figure.
Push the cl
ip to disconnect the connector.
2
1
3
NOTE
Maintenance 4. Cable
88
LS20-B R ev.4
Connector (white) for the power cable is difficult to
disconnect for safety purpose.
To
disconnect the connector, securely push the clip.
If you cannot disconnect it, push the connector once, and then disconnect it by pushing
the
clip.
Do not pull the cables. Doing so may result in
disconnection.
Do not remove the M/C cable form the plate.
NOTE
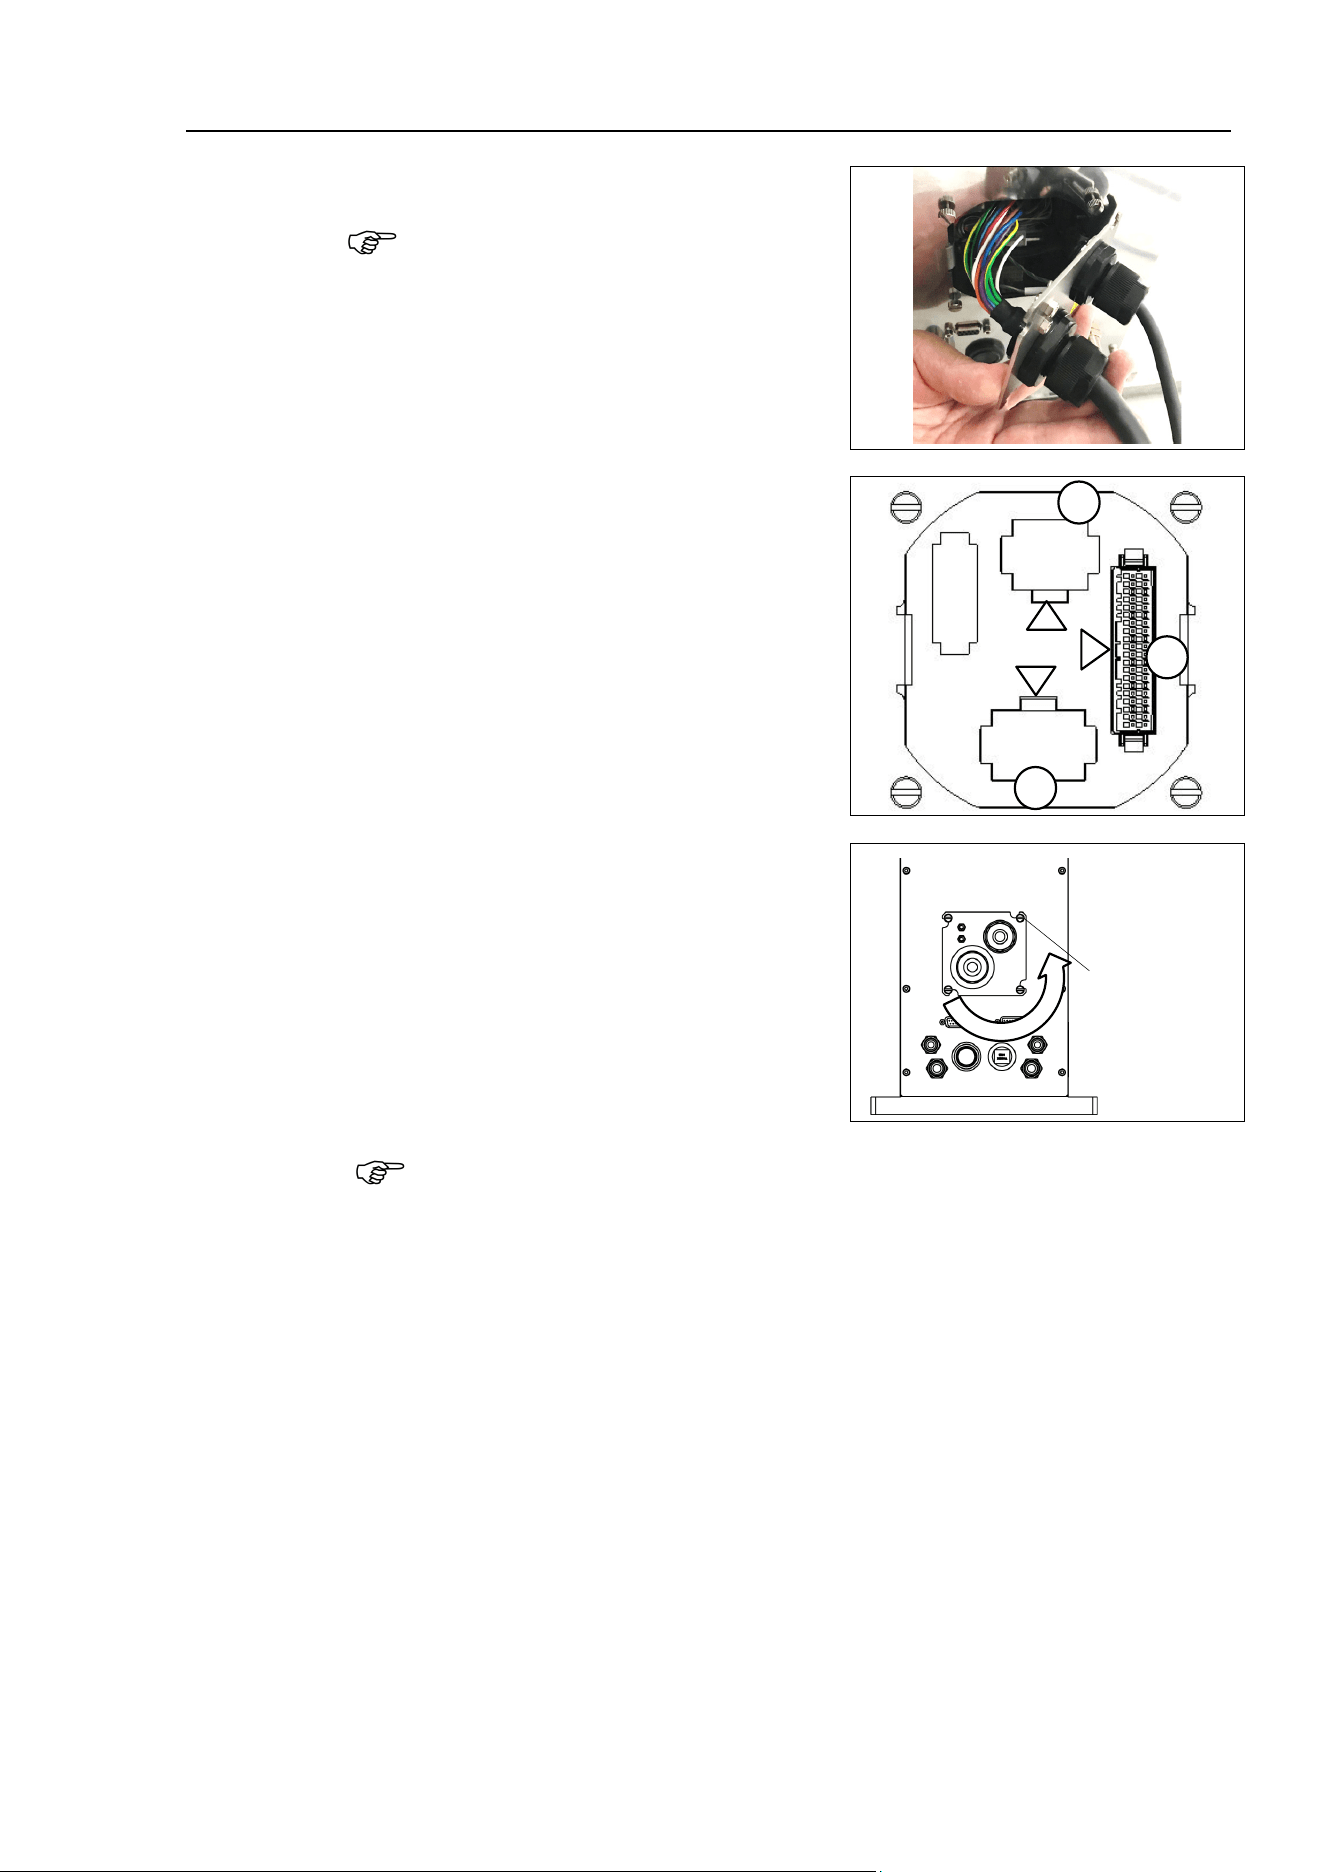
Maintenance 4. Cable
LS20-B Rev.4 89
M/C
cable
Installation
(
1)
Set
the M/C cable as shown on the right.
Be careful with
the direction of the plate.
(2)
Connect the
following connectors in the
order as shown
on the right.
2
3
1
(3)
Slide
the plate to install it.
Finger screws : 4-M3×10
Tightening torque : 0.6±0.1 N·m
Finger Screws
4-M3×10
Slide the plate until it will be parallel to the
base table.
Be careful not to tighten
the screws with the cables get caught on the plate.
(4)
Connect
the following connectors to the controller.
Power cable connector Signal cable connector
(5)
Turn ON the Controller.
NOTE
NOTE
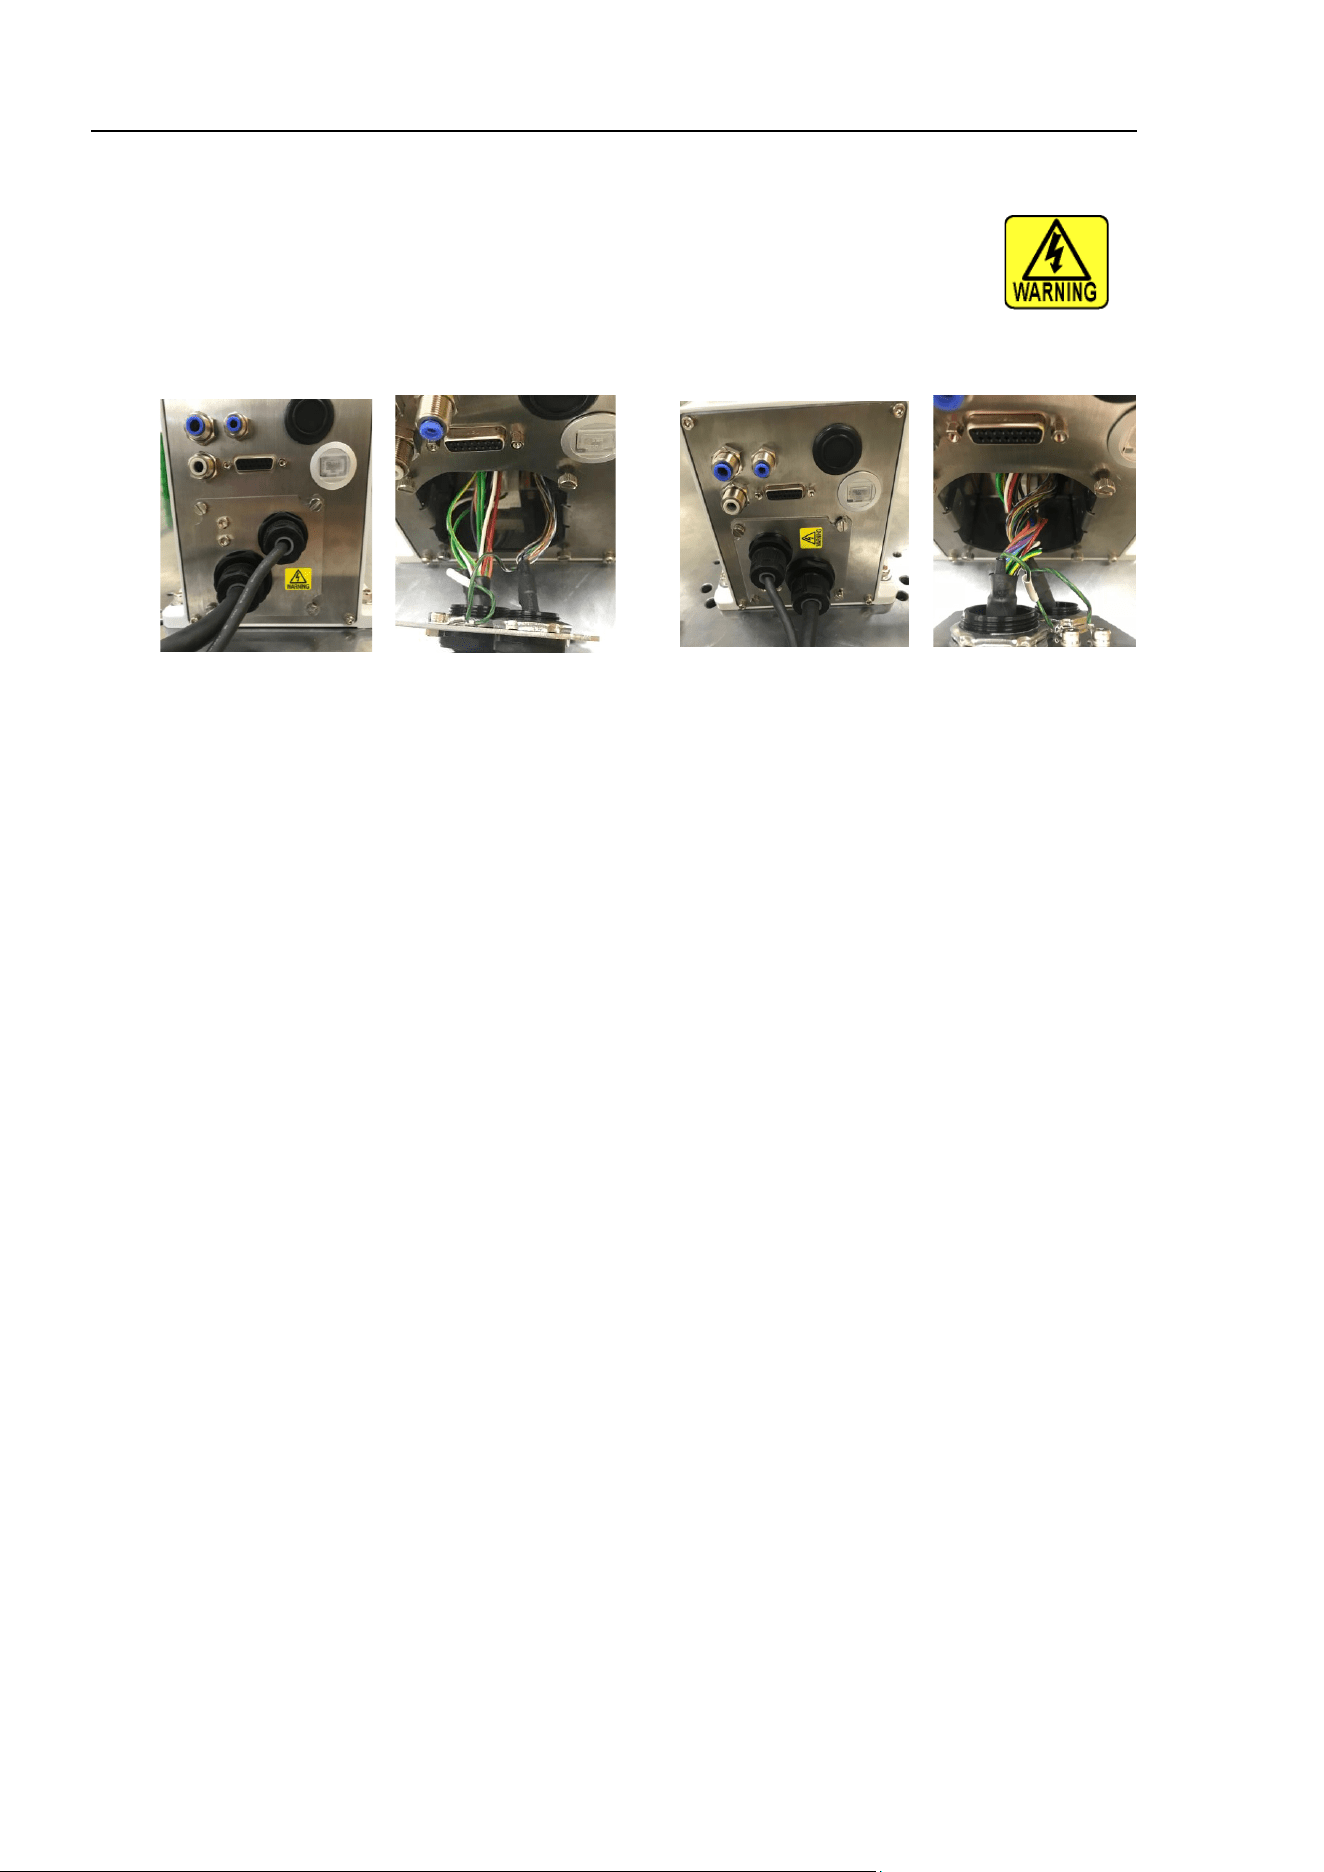
Maintenance 4. Cable
90
LS20-B R ev.4
Direction of the connector sub plate
When installing the plate, be careful for the direction.
Correct direction is where the letters: WARNING of warning label of electric shock will be
parallel to the base table.
If the plate is installed in wrong direction, the cables inside the Manipulator will be twisted
and may result in disconnection.
Correct: Cables are not twisted
Wrong: Cables are twisted
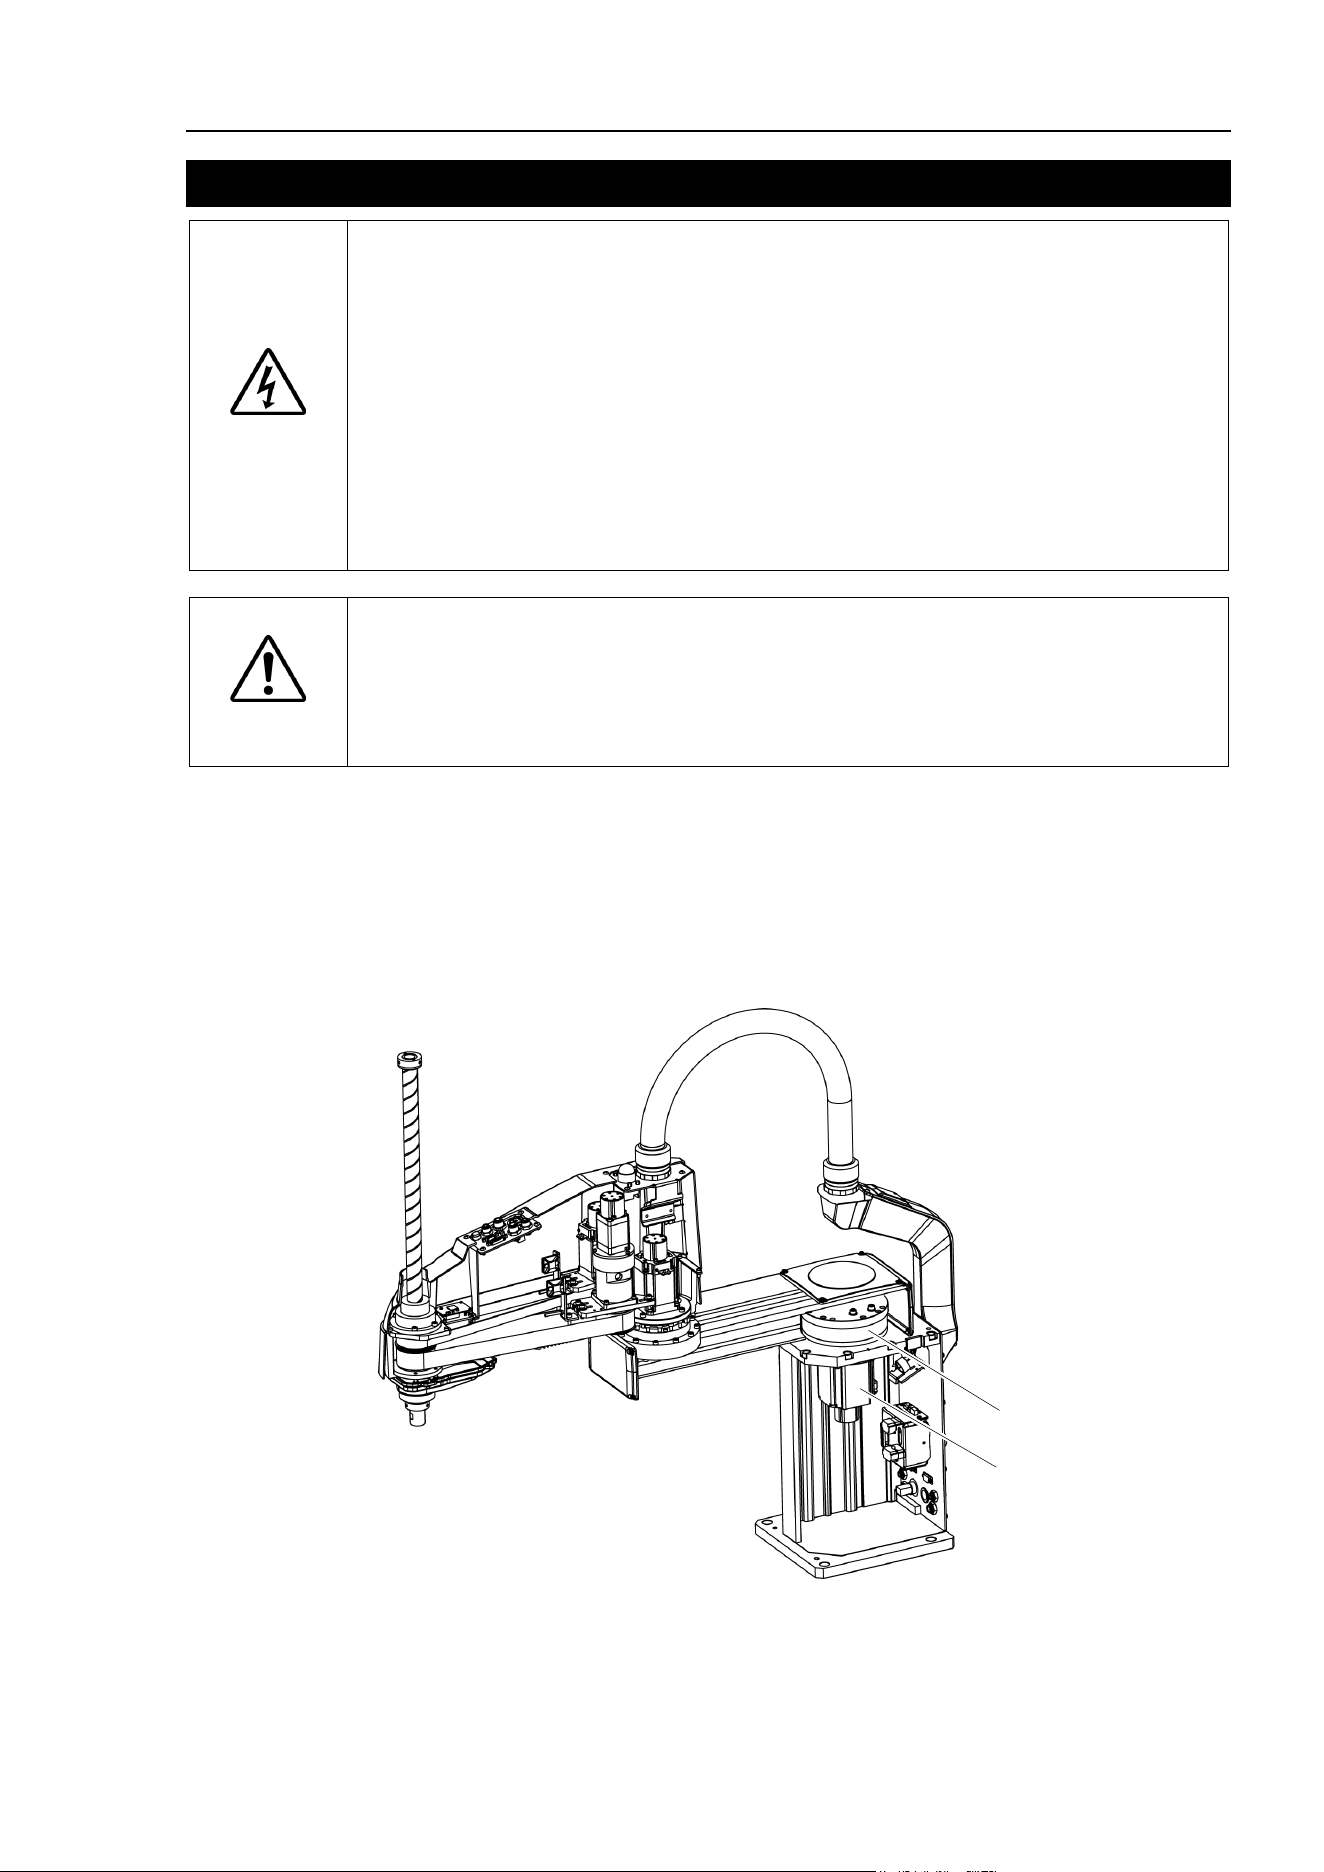
Maintenance 5. Joint #1
LS20-B Rev.4 91
5. Joint #1
WARNING
■
Do not connect or disconnect the motor connectors while the power to the robot
system is turned ON. Connecting or disconnecting the motor connectors
with
the power ON is extremely hazardous and may result
in serious bodily injury as
the Manipulator may mo
ve abnormally, and also may result in electric shock
and/or malfunction of the robot system.
■
To shut off power to the robot system, disconnect the power plug from the power
source. Be sure to connect the AC power cable to a power receptacle.
DO NOT connect it directly to a factory power source.
■
Before performing any replacement procedure, turn OFF the Controller and
related equipment,
and then disconnect the power plug from the power source.
Performing any replacement procedure with the power ON is extremely hazardous
and may result in
electric shock and/or malfunction of the robot system.
CAUTION
■
Be careful not to apply excessive shock to the motor shaft when replacing
the
motor
s. The shock may shorten the life cycle of the motors and encoder and/or
damage them.
■
Never disassemble the motor and encoder. A disassembled motor and encoder
will cause a positional gap and cannot be used
again.
After parts have been replaced (motors, reduction gear units, brakes, timing belts, ball screw
spline unit, etc.), the Manipulator cannot operate properly because a mismatch exists
between the origin stored in each motor and its corresponding origin stored in the Controller.
After replacing the parts, it is necessary to match these origins.
The process of aligning the two origins is called “Calibration”.
Refer to Maintenance: 13. Calibration to execute the calibration.
Joint #1 Reduction Gear Unit
Joint #1 Motor
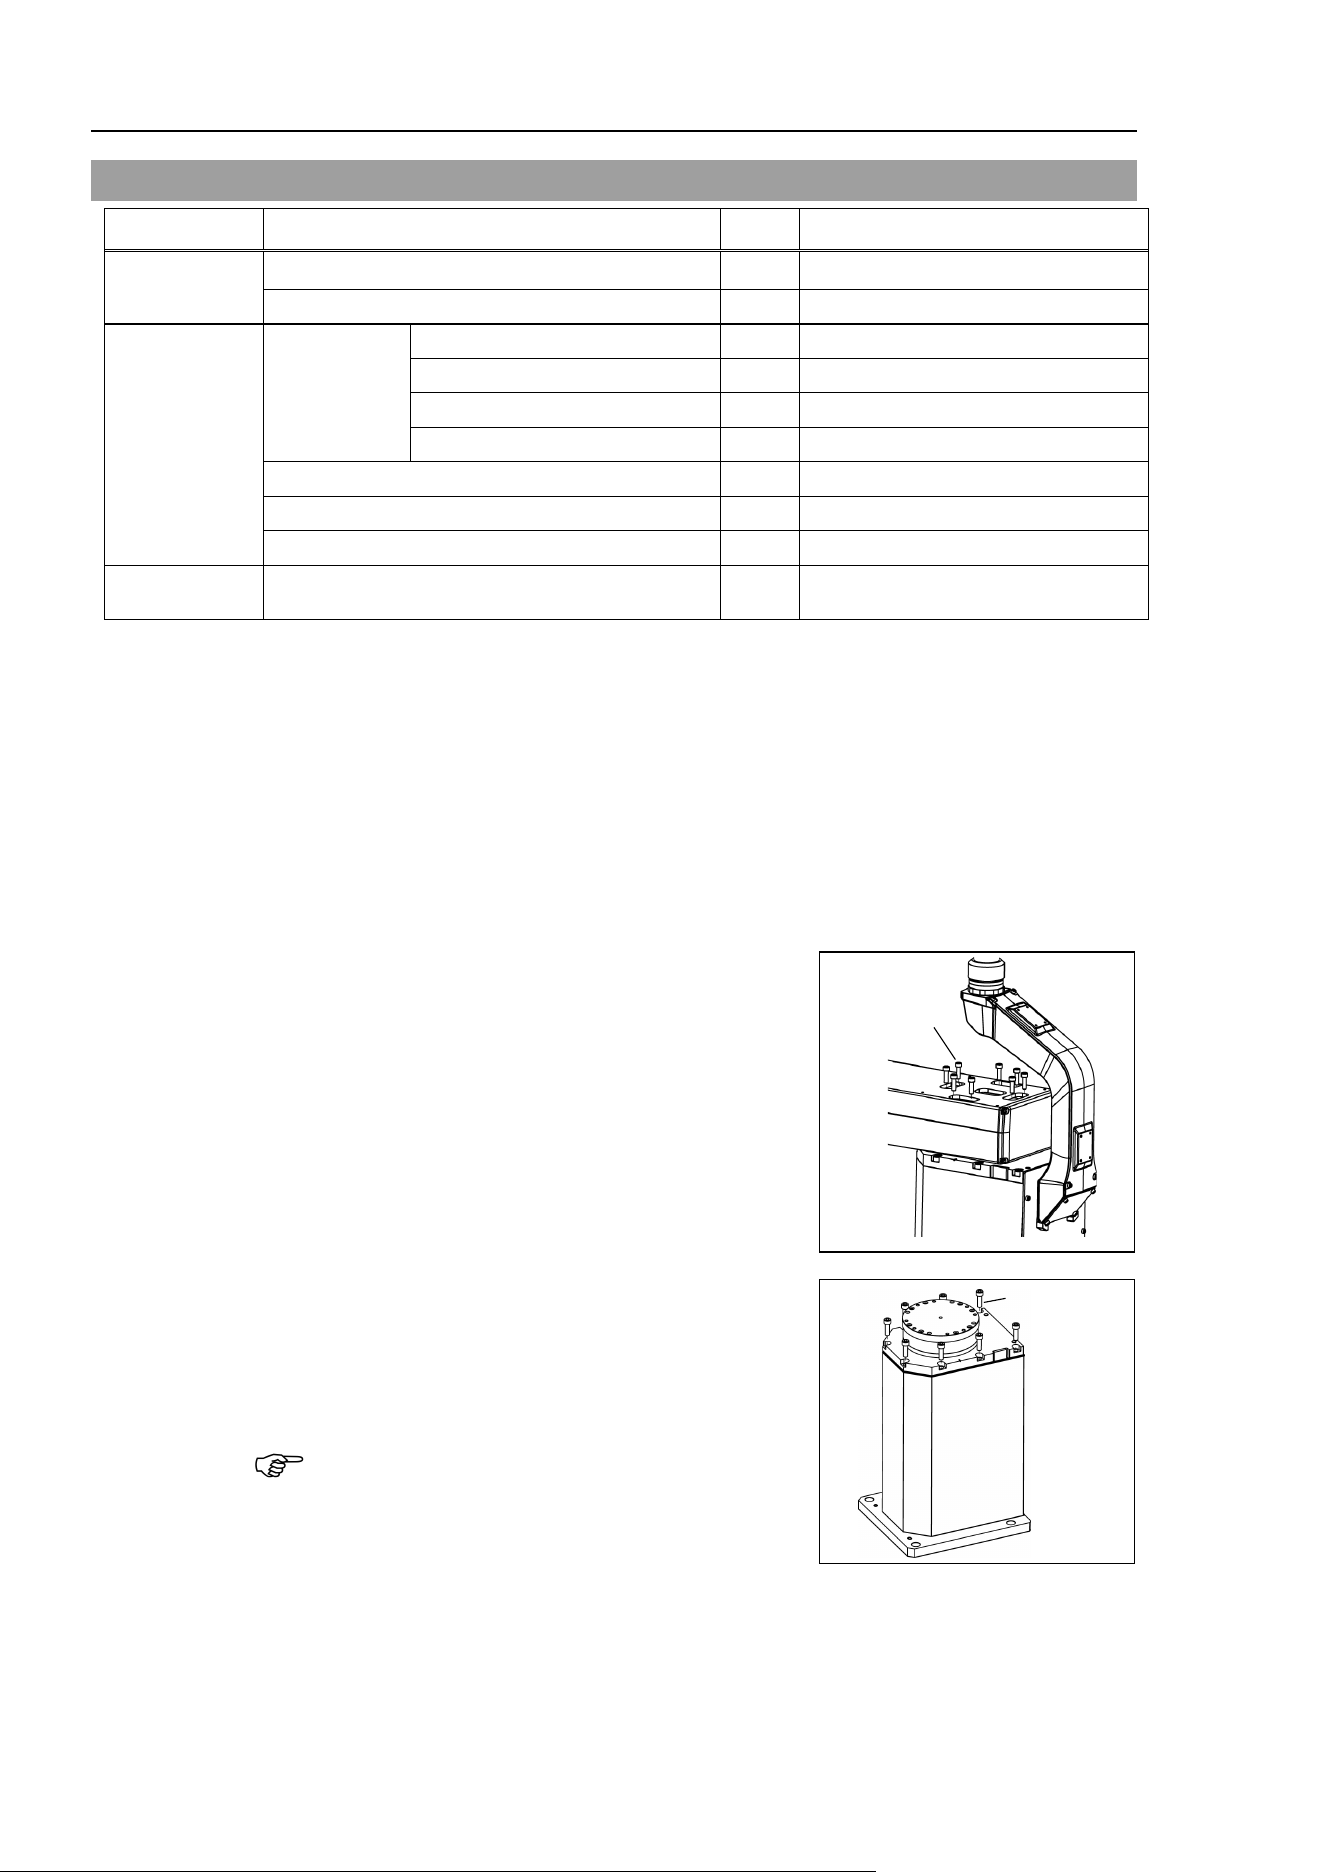
Maintenance 5. Joint #1
92
LS20-B R ev.4
5.1 Replacing Joint #1 Motor
Name Qty. Note
Maintenance
parts
AC Servo Motor (750W)
1
2202238
O-ring
1
1618361
Tools
Hexagonal
wrench
width across flats: 2.5 mm
1
For M5 set screw
width across flats: 4 mm
1
For M5 screw
width across flats: 5 mm
1
For M6 screw
width across flats: 6 mm
1
For M8 screw
Cross-point screwdriver (#2)
1
For M4 screw
Torque wrench
1
Wiping cloth
1
For wiping grease
Maintenance
parts
Grease (SK-1A) - -
Joint #
1 motor
Removal
(1)
Remove the Connector Plate.
F
or details, refer to Maintenance: 3.4 Connector Plate.
(2)
Disconnect the connector.
Connectors: X41, X211 (Hold the clip to remove.)
(3)
Remove the Arm #1 cover.
F
or details, refer to Maintenance: 3.3 Arm #1 cover.
(4)
Remove
the Arm #1 mounting bolt on the Joint
#1 side and remove the Arm 1.
8-M6×20
+Plain washer
(5)
Remove the screws mounting the Top Plate on
the Base.
8-M8×25
(6)
Hold up the Joint #1 unit and remove from the
Base.
The Joint #1 motor can be replaced
while the
Arm #1 and the Top plate are mounted.
Refer
to the
next page for replacement steps.
NOTE
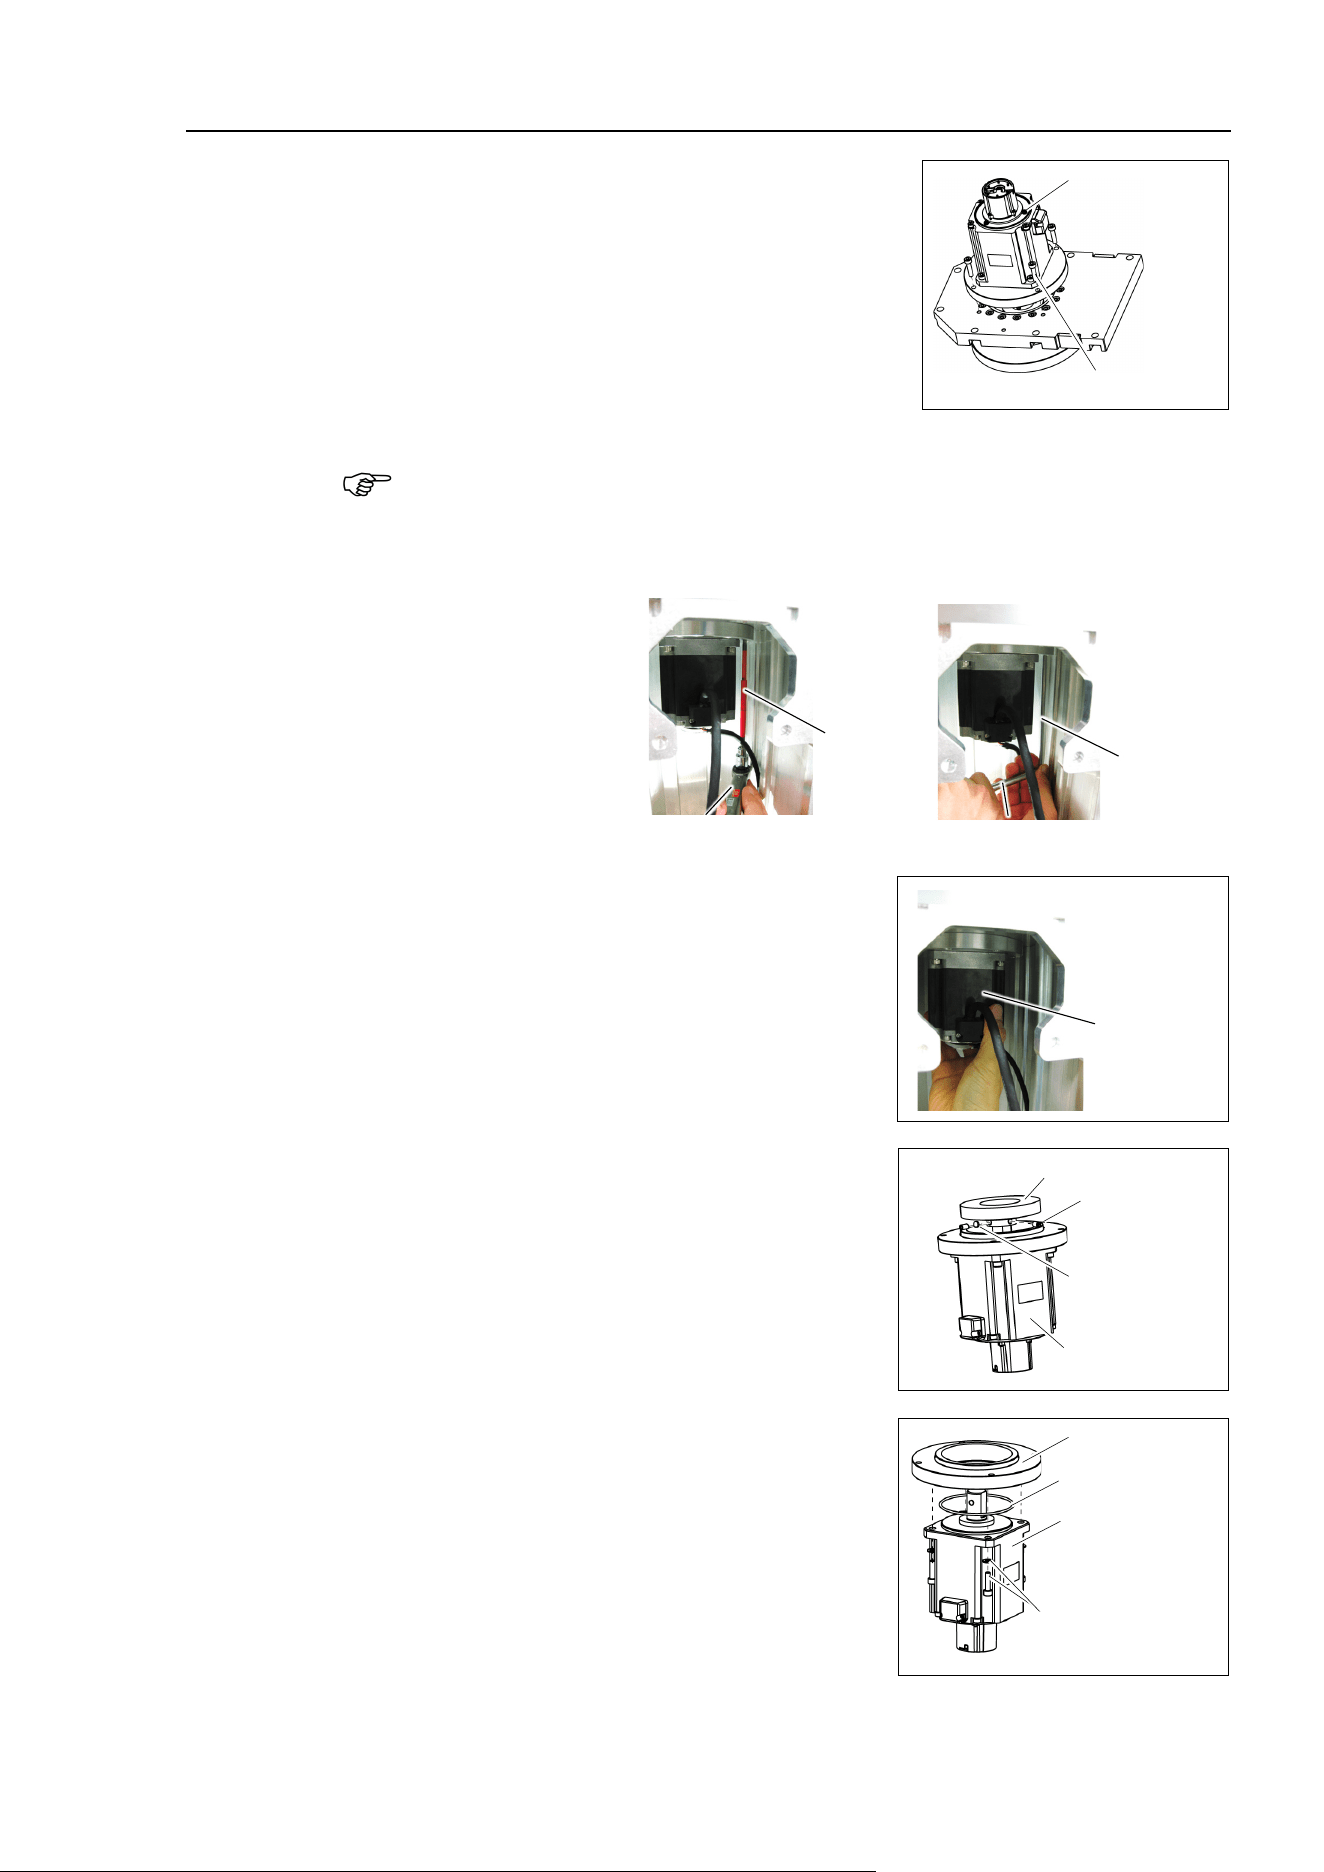
Maintenance 5. Joint #1
LS20-B Rev.4 93
(7)
Loosen the motor mounting screws on the
motor
flange and remove the motor
unit
There is an O
-ring between Top Plate and the
motor flange.
Be sure to keep the O-ring.
4-M5×15
Joint #1
Motor Unit
The motor can be removed while the Arm #1 and the Top plate are mounted.
When removing the motor with the Top plate
mounted, use the torque wrench with
the
long hexagonal bit, or lengthen the general hexagonal wrench by using the metal
pipe
to loosen the screws.
Metal pipe
Torque wrench
Long
hexagonal
bit
General
hexagonal
wrench
After loosening the screws, rotate the motor to
pull out.
If the motor is hard to pull out, pull
the motor while rotating the Arm #1 slowly.
Pull out while
rotating
(8)
Remove the waveform generator from the
Joint
#1 motor.
There is a brass bushing in one of the set
screw
holes.
Be sure to keep the bushing.
Set Screws
2-M5×8
M5 Bushing
Waveform Generator
Joint #1
Motor
(9)
Remove the motor mounting screws
, and then
remove the motor flange and O
-ring.
4-M5×18
+Plain washer
Joint #1 Motor
Motor Flange
O-ring
NOTE
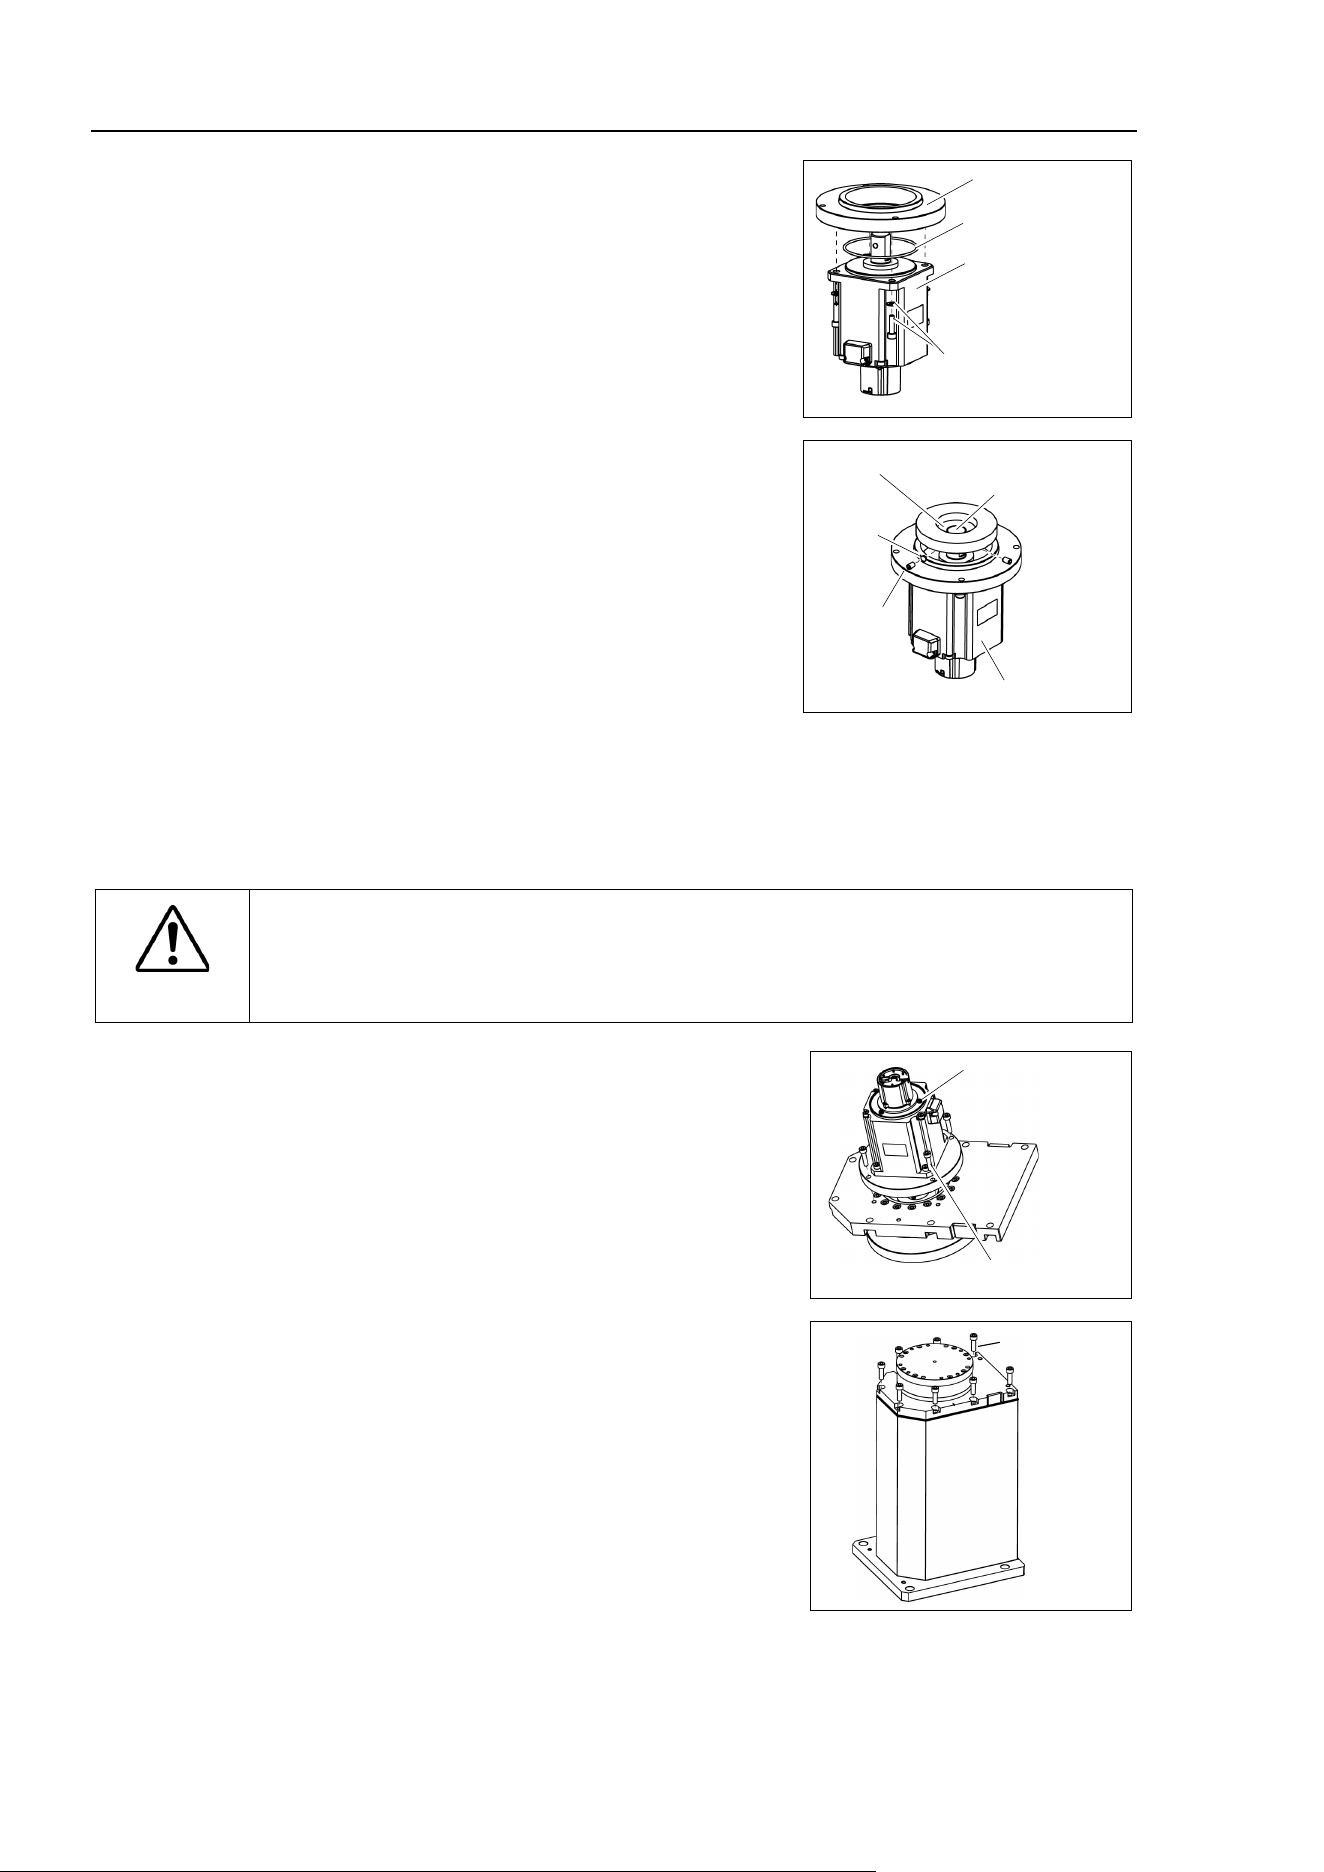
Maintenance 5. Joint #1
94
LS20-B R ev.4
Joint #1 motor
Installation
(1)
Put the O
-ring on the motor mounting surface
and
mount the motor flange.
4-M5×18
+ Plain washer
Joint #1 Motor
Motor Flange
O-ring
(2)
Apply grease (SK
-1A) to the between the
waveform generator and motor.
Grease volume : 6 g
Mount the waveform generator on the Joint
#1
motor.
Be sure to align the end face of the
waveform generator to the end face of the
motor shaft.
Tighten one of the set screws vertically on the
flat face of the motor shaft.
Insert a bushing
into the other set screw hole to prevent damage
to the motor shaft.
Set screws
2-M5×8
M5
Bushing
End face of Waveform Generator
Joint #1 Motor
End face of Motor
CAUTION
■
See the figure above for the orientation of the waveform generator.
Be sure to
install the waveform generator properly.
Improper installation of the waveform
generator will result in improper
function of the Manipulator.
(3)
Set an O
-ring on the motor flange and assemble
the
Top Plate.
To insert the motor, turn it slowly from side to
side by hand and push in.
4-M5×15
Joint #1
Motor Unit
(4)
Mount the Joint #1 unit on the
Base.
Secure the Joint #1 motor cables facing toward
the back of the Base.
8-M8×25
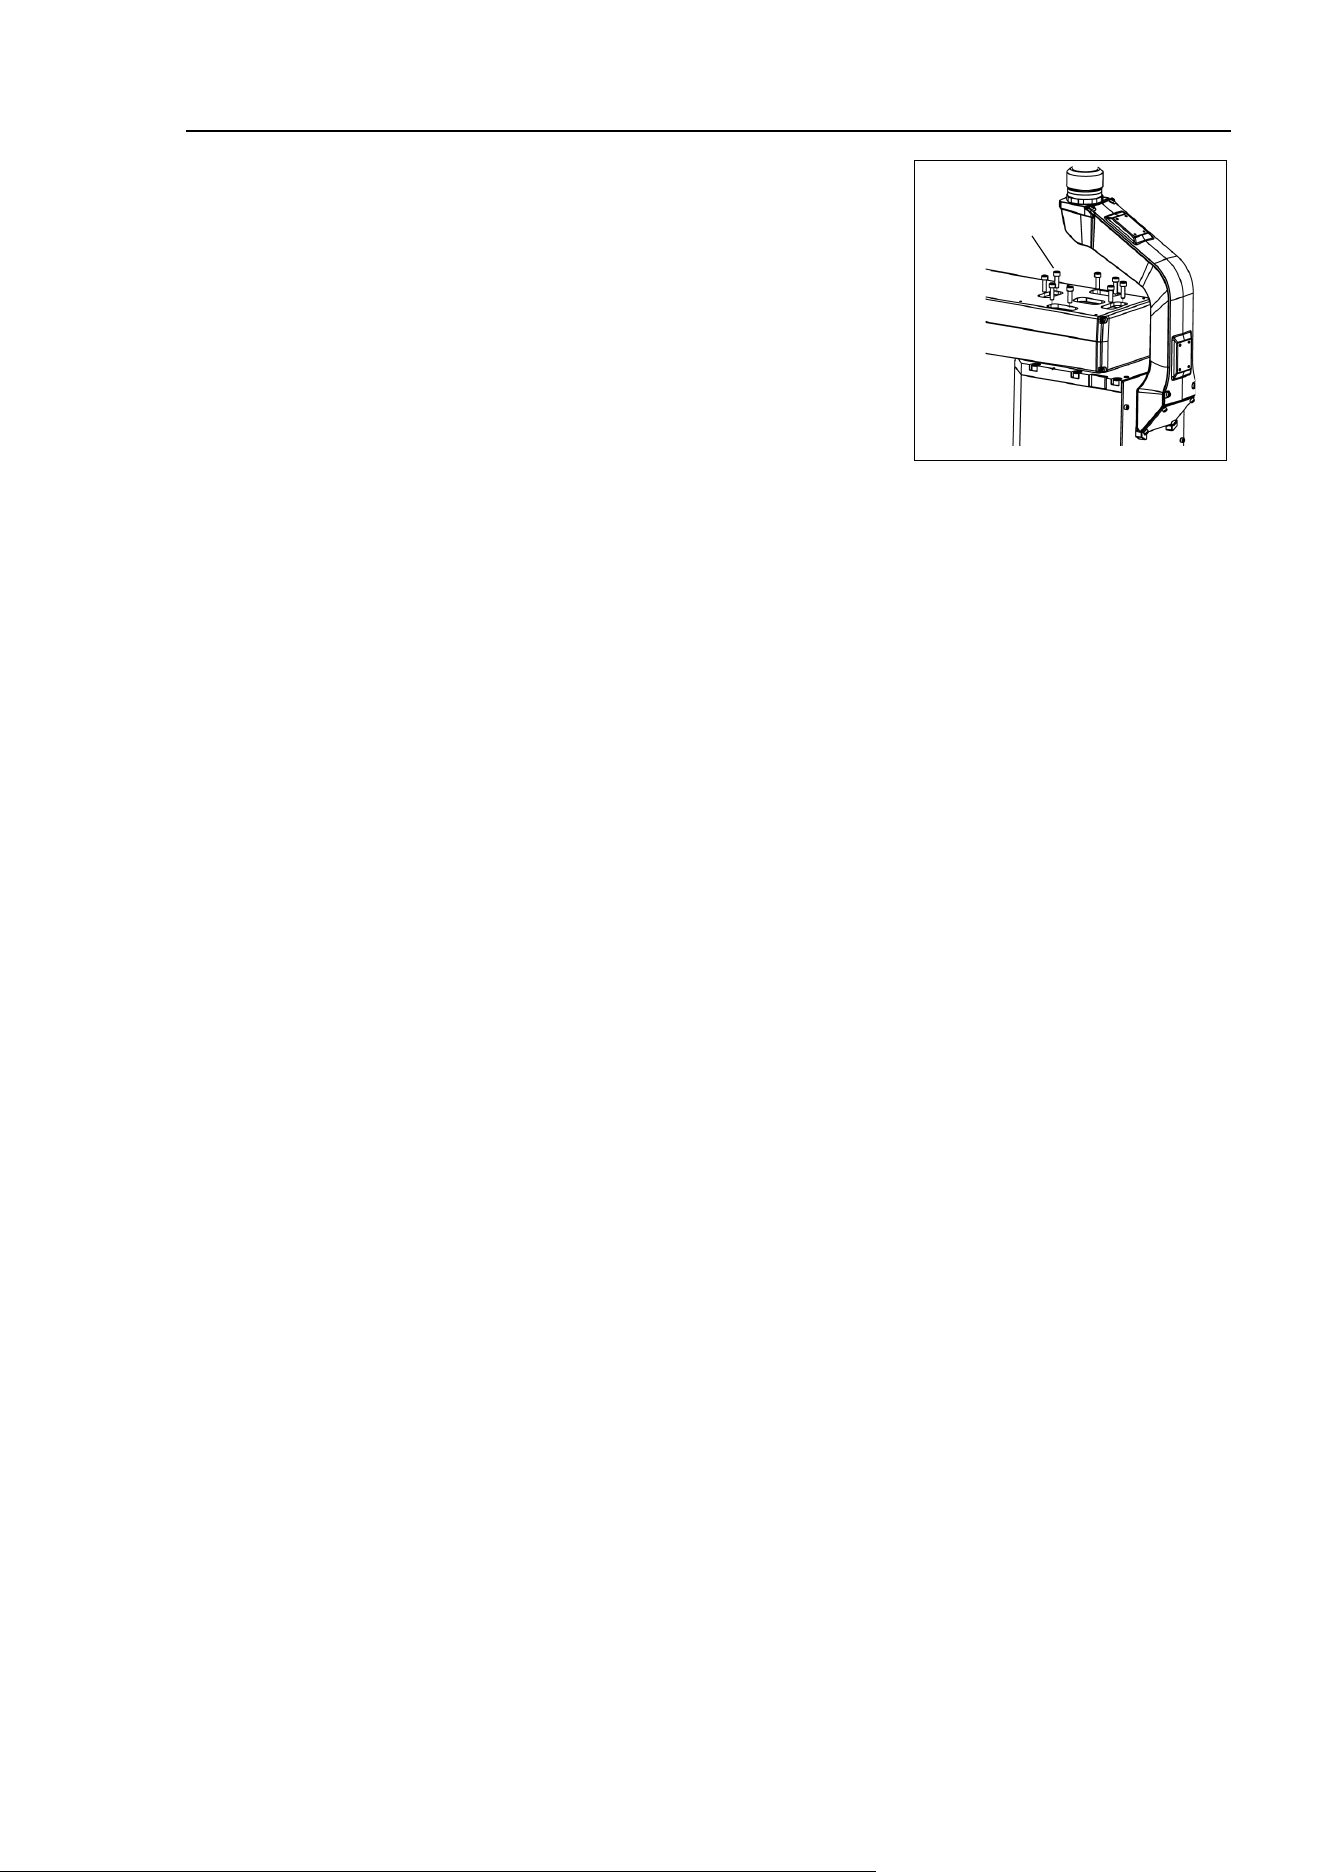
Maintenance 5. Joint #1
LS20-B Rev.4 95
(5)
Mount the Arm #1 to the Joint #1 unit.
Tightening torque: 18 N·m
Operating the Manipulator with improper
tightening torque may cause positioning gap and
damage on the screw and screw hole.
8-M6×20
+ Plain washer
(6)
Mount the cover to the Arm #1.
For details, refer to Maintenance: 3.3 Arm #1 Cover.
(7)
Connect the following connectors
.
Connectors: X41, X211
(8)
Mount the Connector Plate.
For details, refer to
Maintenance 3.4 Connector Plate.
(9)
Check if the Joint #1 moves in a Jog motion by operating from
EPSON RC+ menu
-
[
Tools]-[Robot Manager]-[Jog & Teach].
If the Manipulator oscillates with
MotorON and the following errors are detected,
Error 5041: Motor torque output failure in low power state.
Error 4241: Over speed during low power mode was detected.
or when the joint other than Joint #1 moves, the connector for the other joint might be
connected to the Joint #1 motor. Check the connector connection.
(
10)
Execute the calibration for the Joint #1.
For details refer to Maintenance: 13. Calibration.
NOTE
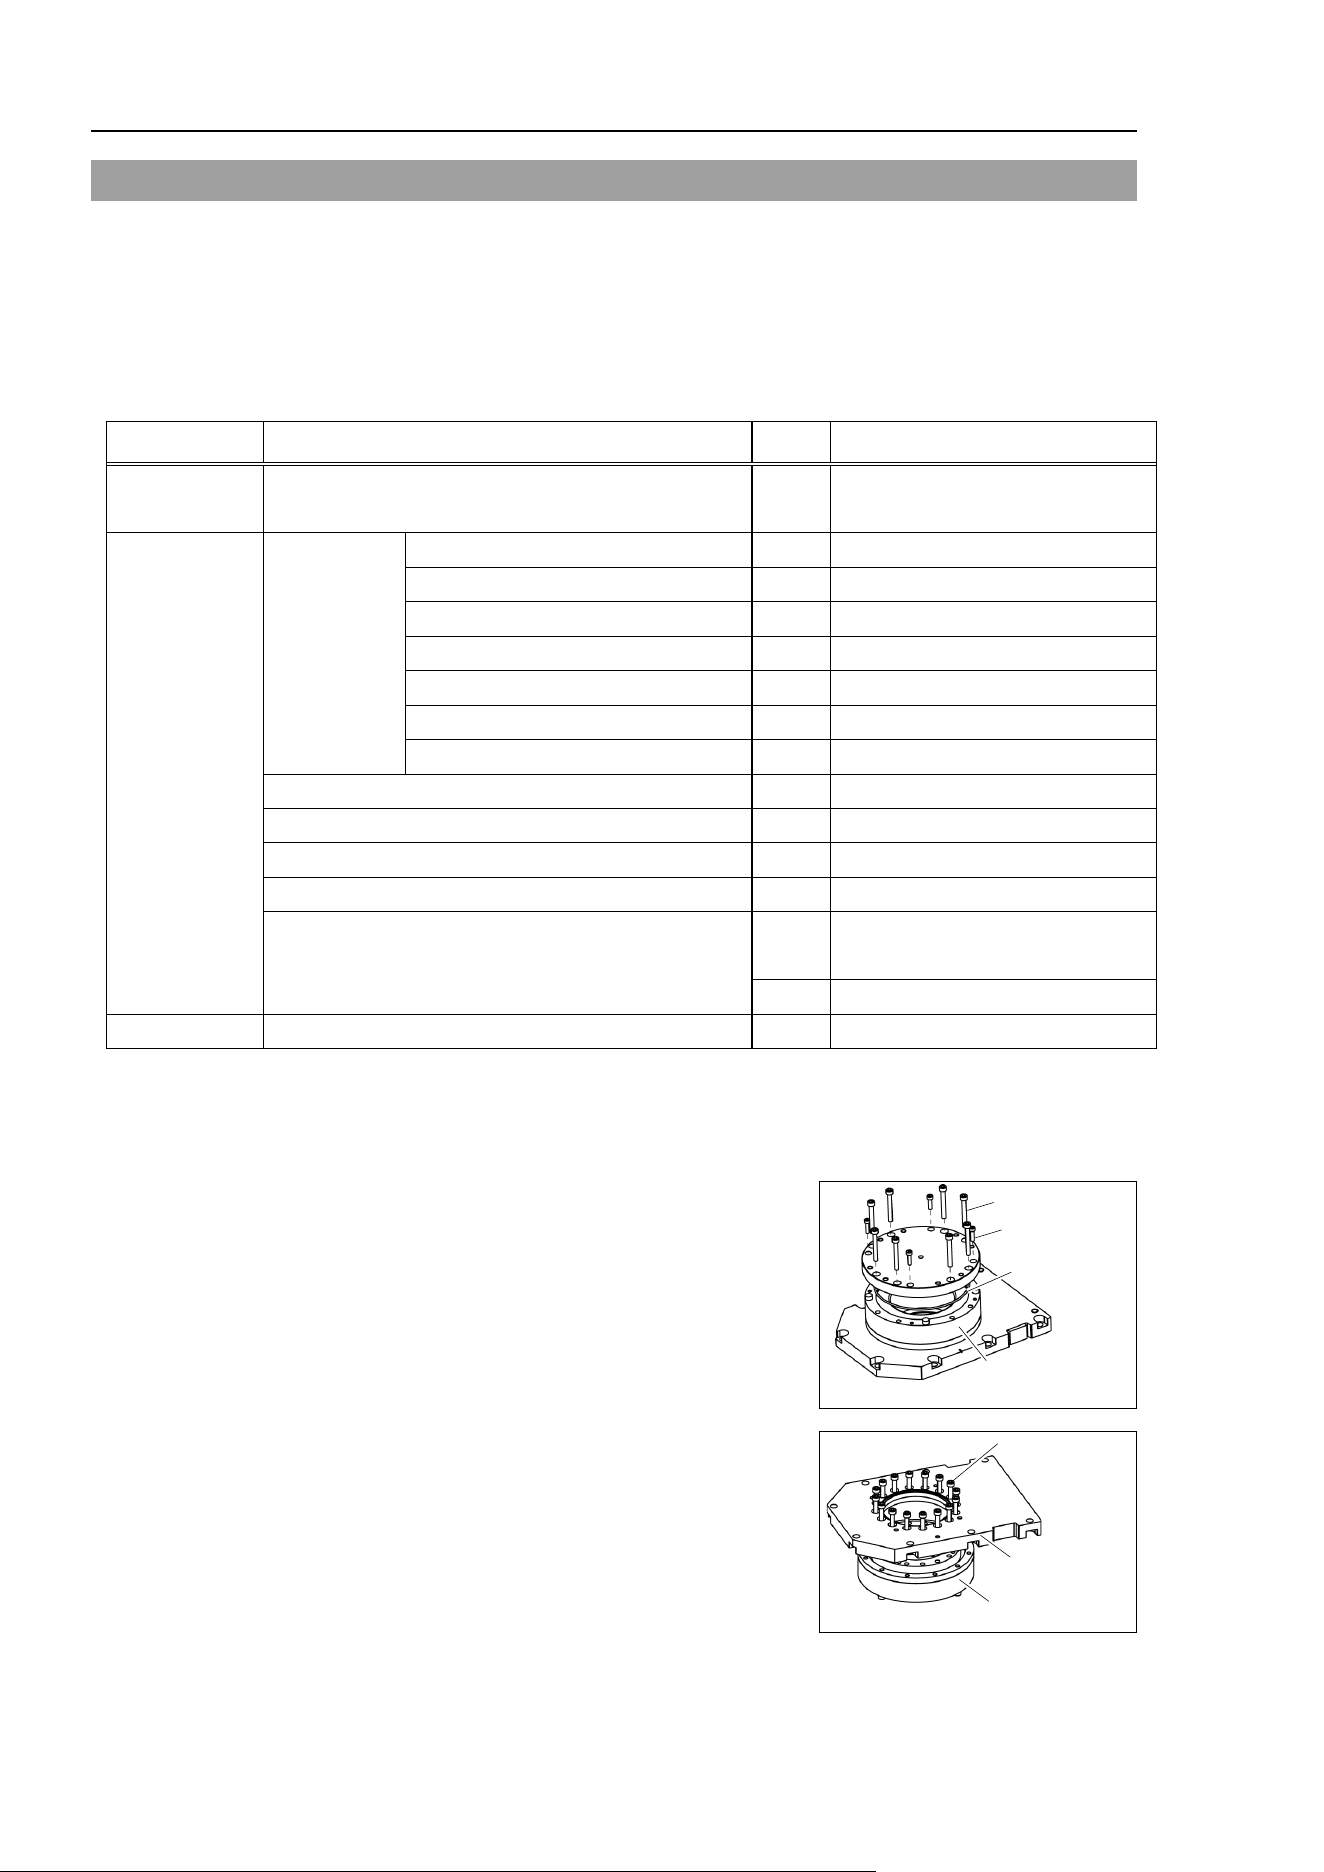
Maintenance 5. Joint #1
96
LS20-B R ev.4
5.2 Replacing Joint #1 Reduction Gear Unit
A reduction gear unit consists of the following three parts. When replacing the reduction
gear unit, be sure to always replace the waveform generator, flexspline, and circular spline
all together as one set.
Waveform generator, Flexspline, Circular spline
For details of the reduction gear unit, refer to Maintenance: 14. Maintenance Parts List.
Name Qty. Note
Maintenance
Part
Joint #1 Reduction Gear Unit 1 1646483
Tools
Hexagonal
wrench
width across flats: 2.5 mm
1
For M5 set screw
width across flats: 3 mm
1
For M4 screw
width across flats: 4 mm
1
For M5 screw
width across flats: 5 mm
1
For M6 screw
width across flats: 6 mm
1
For M8 screw
width across flats: 2.5 mm
1
For M5 set screw
width across flats: 3 mm
1
For M4 screw
Cross-point screwdriver (#2)
1
For M4 screw
Torque wrench
1
Nippers
1
Spatula
1
For apply grease
Wiping cloth
1
For wiping grease
(Motor Flange)
1
For wiping grease (Bolt)
Grease
Grease (SK-1A)
-
-
Joint #1
R
eduction
G
ear Unit
Removal
(1)
Remove the Joint #1 motor unit.
F
ollow the removal steps in Maintenance: 5.1 Replacing Joint #1 Motor.
(2)
Remove the spacer from the reduction gear
unit.
8-M5×40
Spacer
Reduction
Gear Unit
4-M4×15
(3)
Remove the reduction gear unit from the Top
Plate.
16-M5×30
Top Plate
Reduction
Gear Unit
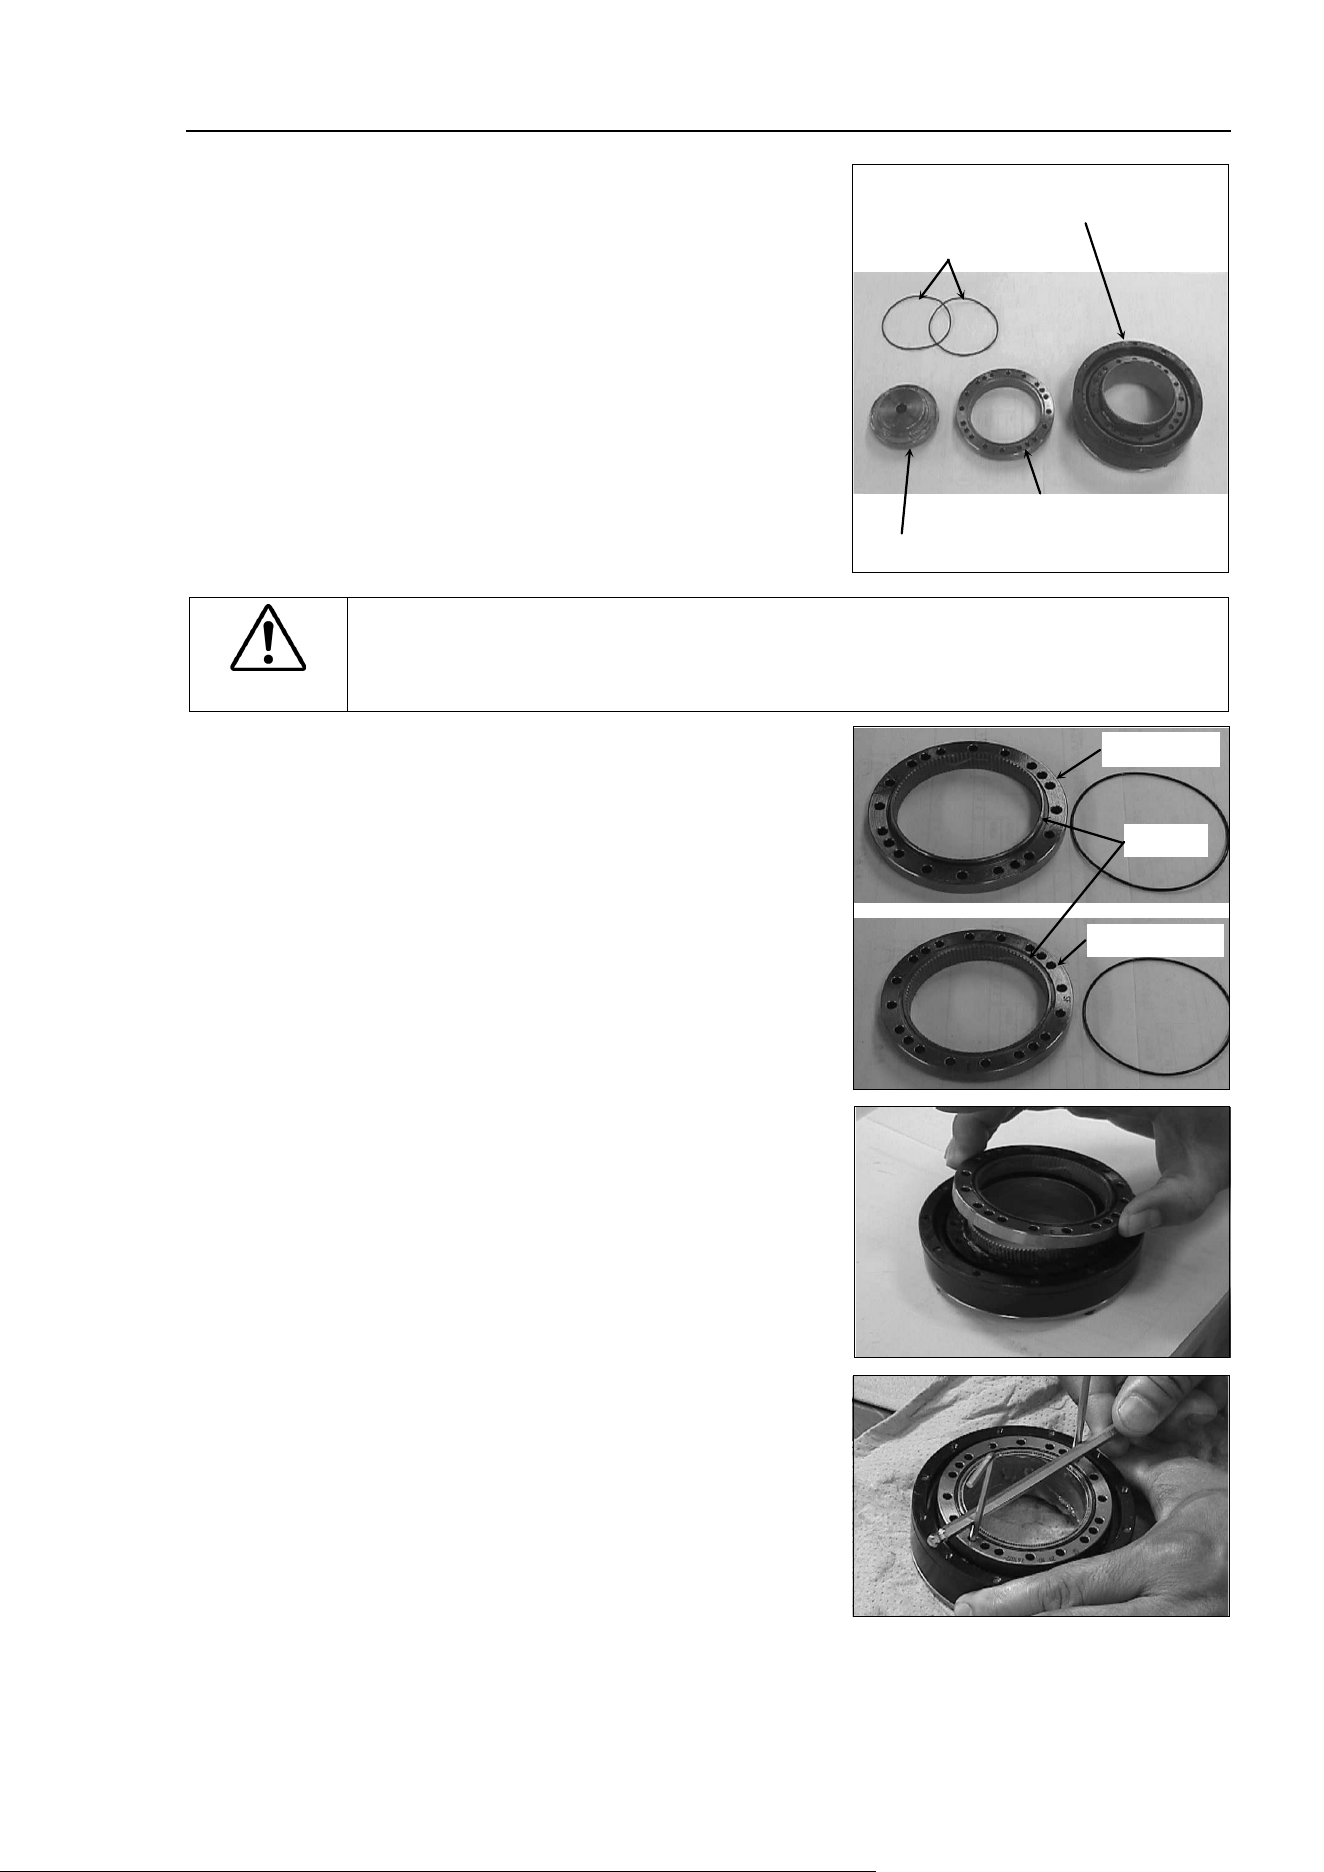
Maintenance 5. Joint #1
LS20-B Rev.4 97
Joint #1
R
eduction
G
ear Unit
Installation
(1)
A
new reduction gear unit contains the
parts shown
in the picture on the right
when it
is unpacked.
The gear grooves of the flexspline,
circular spline
, and the bearings of the
waveform generator
have been greased.
Wipe off excess grease
from the mounting
surfa
ce.
Flexspline and
Cross roller bearing unit
Circular spline
Waveform generator
O-ring
CAUTION
■
Never
adjust (loosen or tighten) the mounting bolts between the flexspline and
cross roller bearing unit.
If the mounting bolts are adjusted, the flexspline and
cross roller bearing unit must be
aligned by the maker of the reduction gear unit.
(2)
Fit the
O-rings into the grooves on both
side
s of the new circular spline.
Make
sure that the rings do not come out of
the grooves.
Convex side
Grooves
The other side
(3)
Face the convex side of the circular spline
down,
and then fit it into the flexspline.
(4)
M
atch the screw holes on the inner ring of
the cross roller bearing unit and the through
holes of the circular spline.
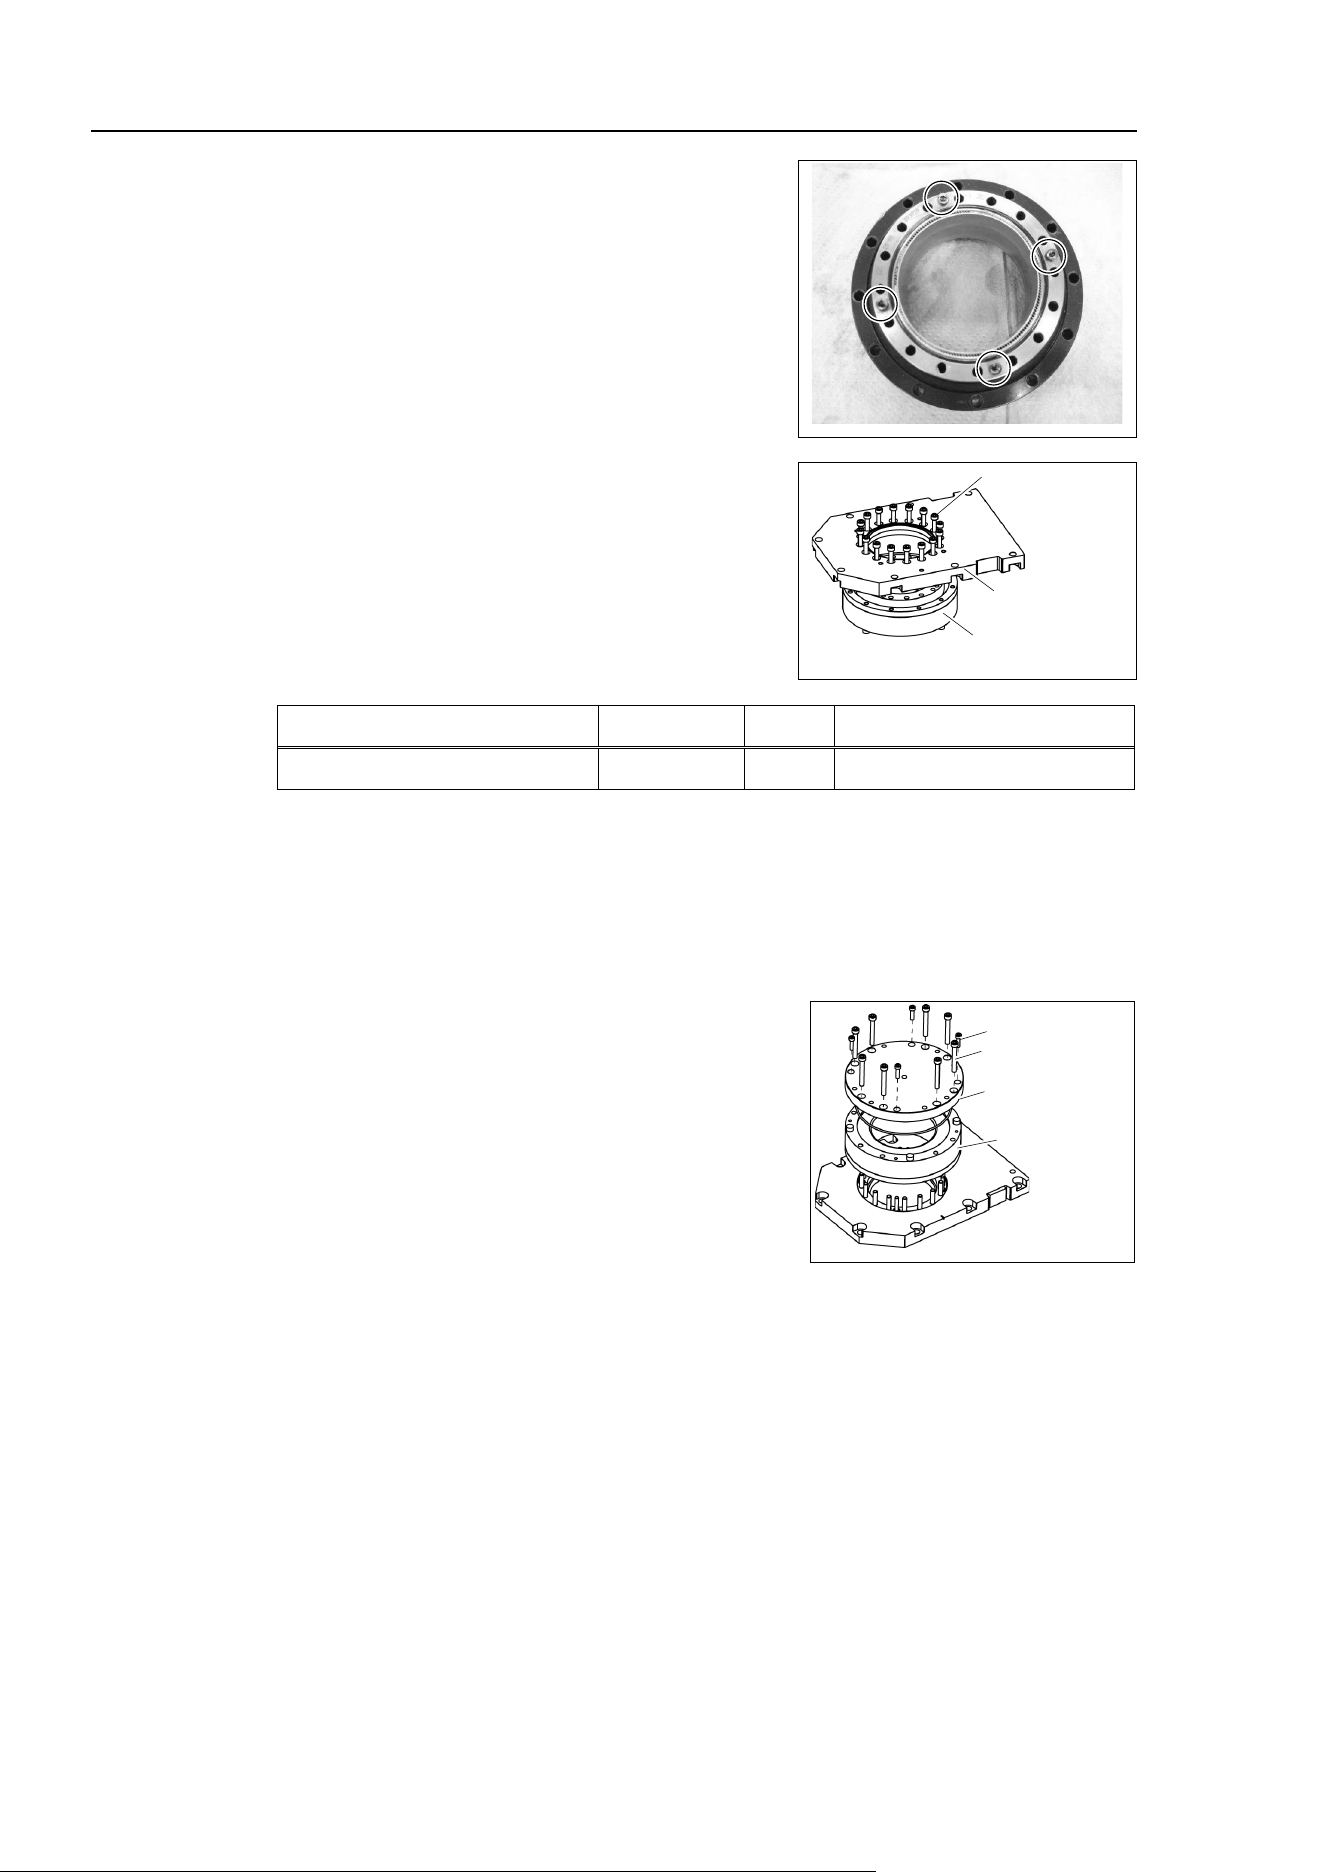
Maintenance 5. Joint #1
98
LS20-B R ev.4
(5)
Secure
the cross roller bearing to the circular
spline
.
4-M4×20
Tightening torque: 4.0 N·m (40.8 kgf·cm)
(6)
Secure
the Top Plate to the circular spline.
Loosely f
asten all bolts in a crisscross pattern so
that
the bolts will be fastened evenly. Then,
using a torque wrench,
tighten each bolt securely
in a crisscross pattern
at the torque specified in
the table below.
16-M5×30
To p plate
Reduction
Gear Unit
Item Bolt type Bolts Tightening torque
Joint #1 reduction gear unit
M5×30
16
10.0 N⋅m (102 kgf⋅cm)
Be careful not to apply too much force since it may damage the parts
.
(7)
Apply grease (SK
-1A) inside the flexspline.
Grease volume : 80 g
(8)
Mount the spacer to the reduction gear unit.
H
exagon socket head cap bolts: 4-M4×15
Tightening torque: 5.5 N·m (56.1 kgf·cm)
Hexagon socket head cap bolts: 8-M5×40
Tightening torque: 10.0 N·m (102 kgf·cm)
8-M5×40
Spacer
Reduction
Gear Unit
4-M4×15
(9)
Mount the Joint #1 motor.
Follow the installation steps in Maintenance: 5.1 Replacing Joint #1 Motor.
NOTE
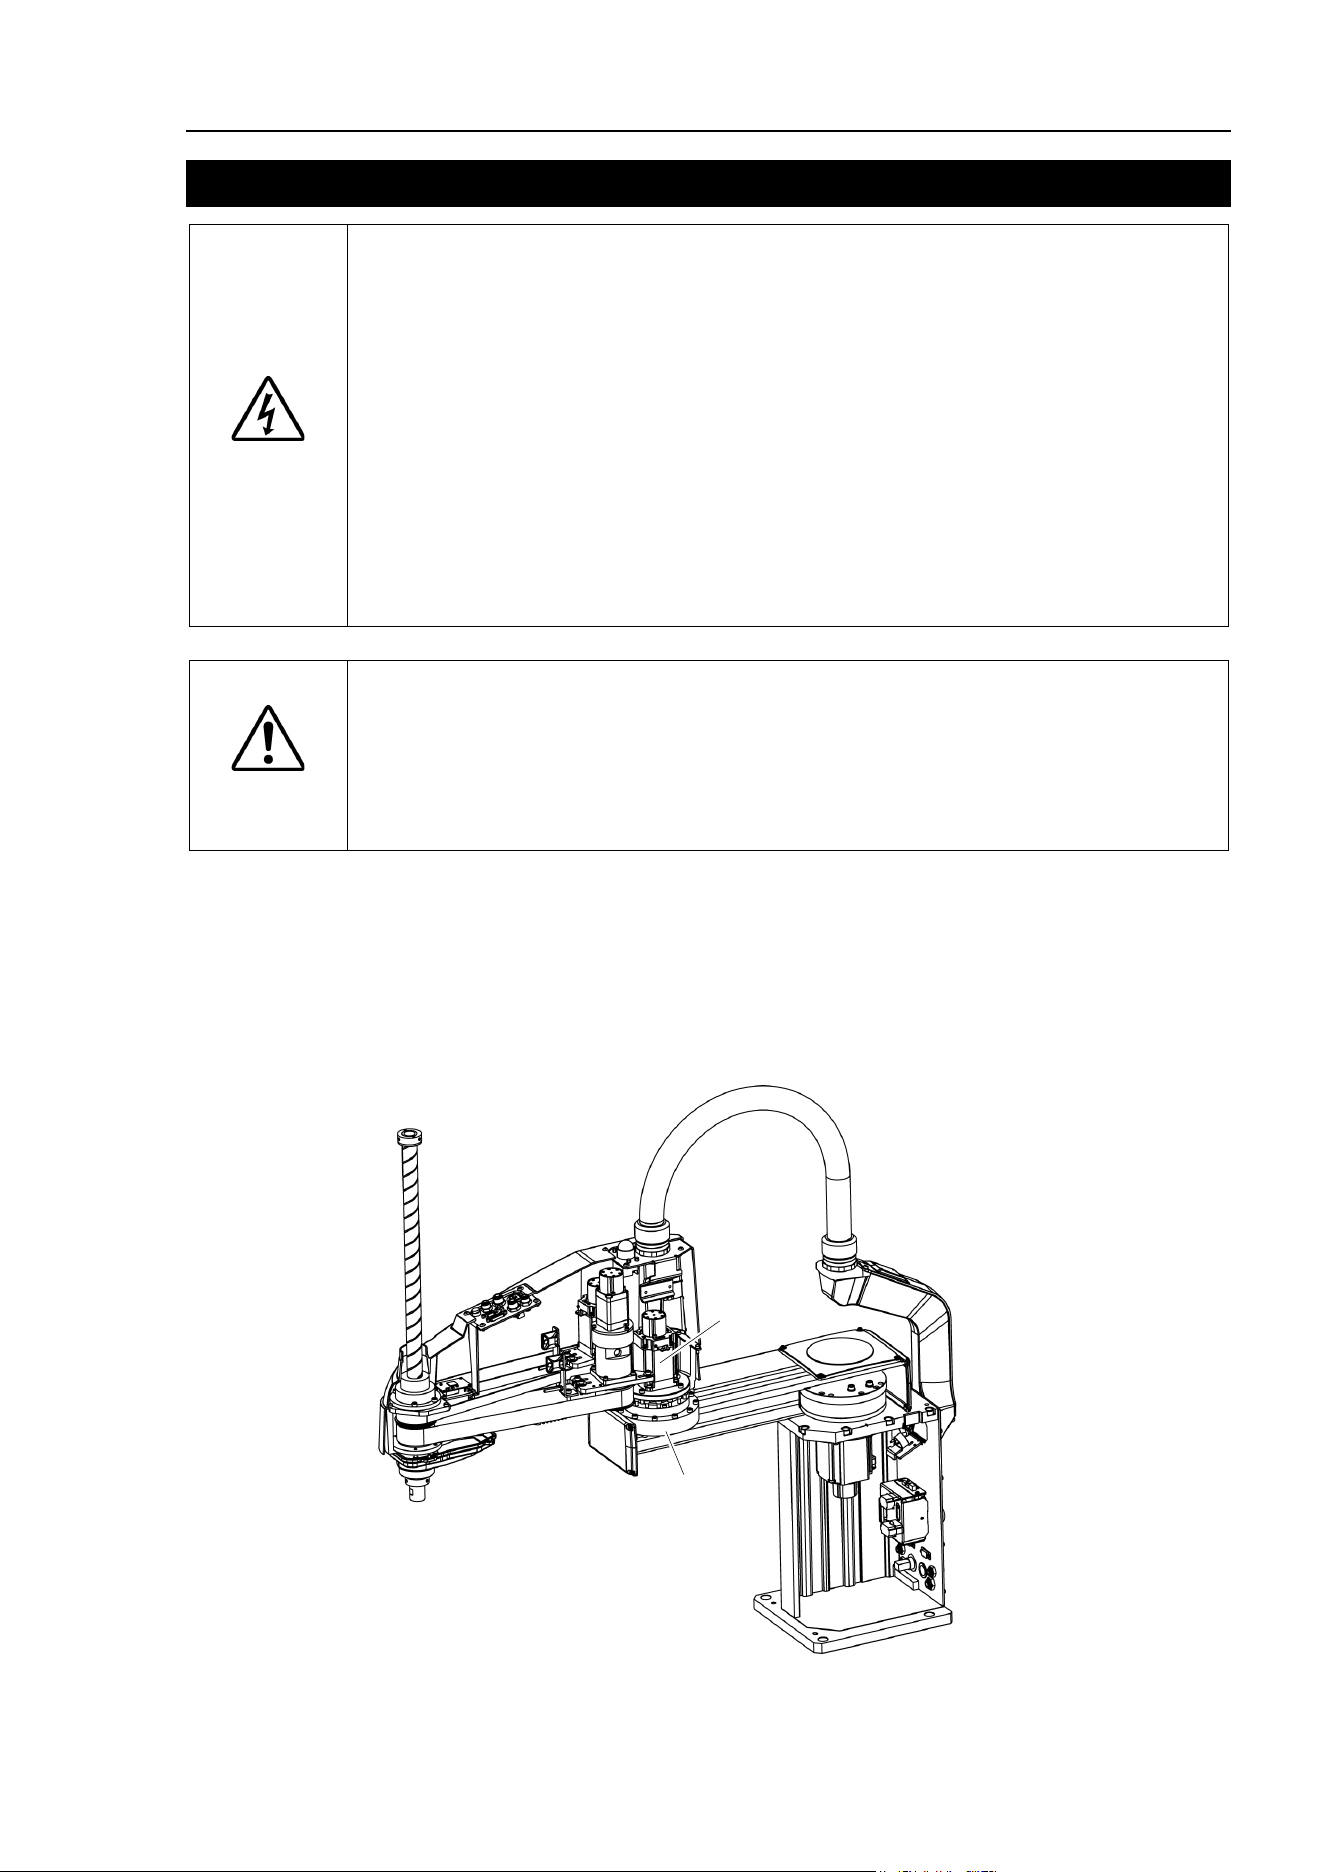
Maintenance 6. Joint #2
LS20-B Rev.4 99
6. Joint #2
WARNING
■
Do not connect or disconnect the motor connectors while the power to the robot
system is turned ON. Connecting or disconnecting the motor connectors
with
the power ON is extremely hazardous and may result
in serious bodily injury as
the Manipulator may mo
ve abnormally, and also may result in electric shock
and/or malfunction of the robot system.
■
To shut off power
to the robot system, disconnect the power plug from the power
source. Be sure to connect the AC power cable to a power receptacle.
DO NOT connect it directly to a factory power source.
■
Before
performing any replacement procedure, turn OFF the Controller and
related equipment,
and then disconnect the power plug from the power source.
Performing any replacement procedure with the power ON is extremely hazardous
and may result in
electric shock and/or malfunction of the robot system.
CAUTION
■
Be careful not to apply excessive shock to the motor shaft when replacing
the
motor
s. The shock may shorten the life cycle of the motors and encoder and/or
damage them.
■
Never disassemble the motor and encoder.
A disassembled motor and encoder
will cause a positional gap and cannot be used
again.
After parts have been replaced (motors, reduction gear units, brakes, timing belts, ball screw
spline unit, etc.), the Manipulator cannot operate properly because a mismatch exists
between the origin stored in each motor and its corresponding origin stored in the Controller.
After replacing the parts, it is necessary to match these origins.
The process of aligning the two origins is called “Calibration”.
Refer to Maintenance: 13. Calibration to execute the calibration.
Joint #2
Motor
Joint #2 Reduction Gear Unit
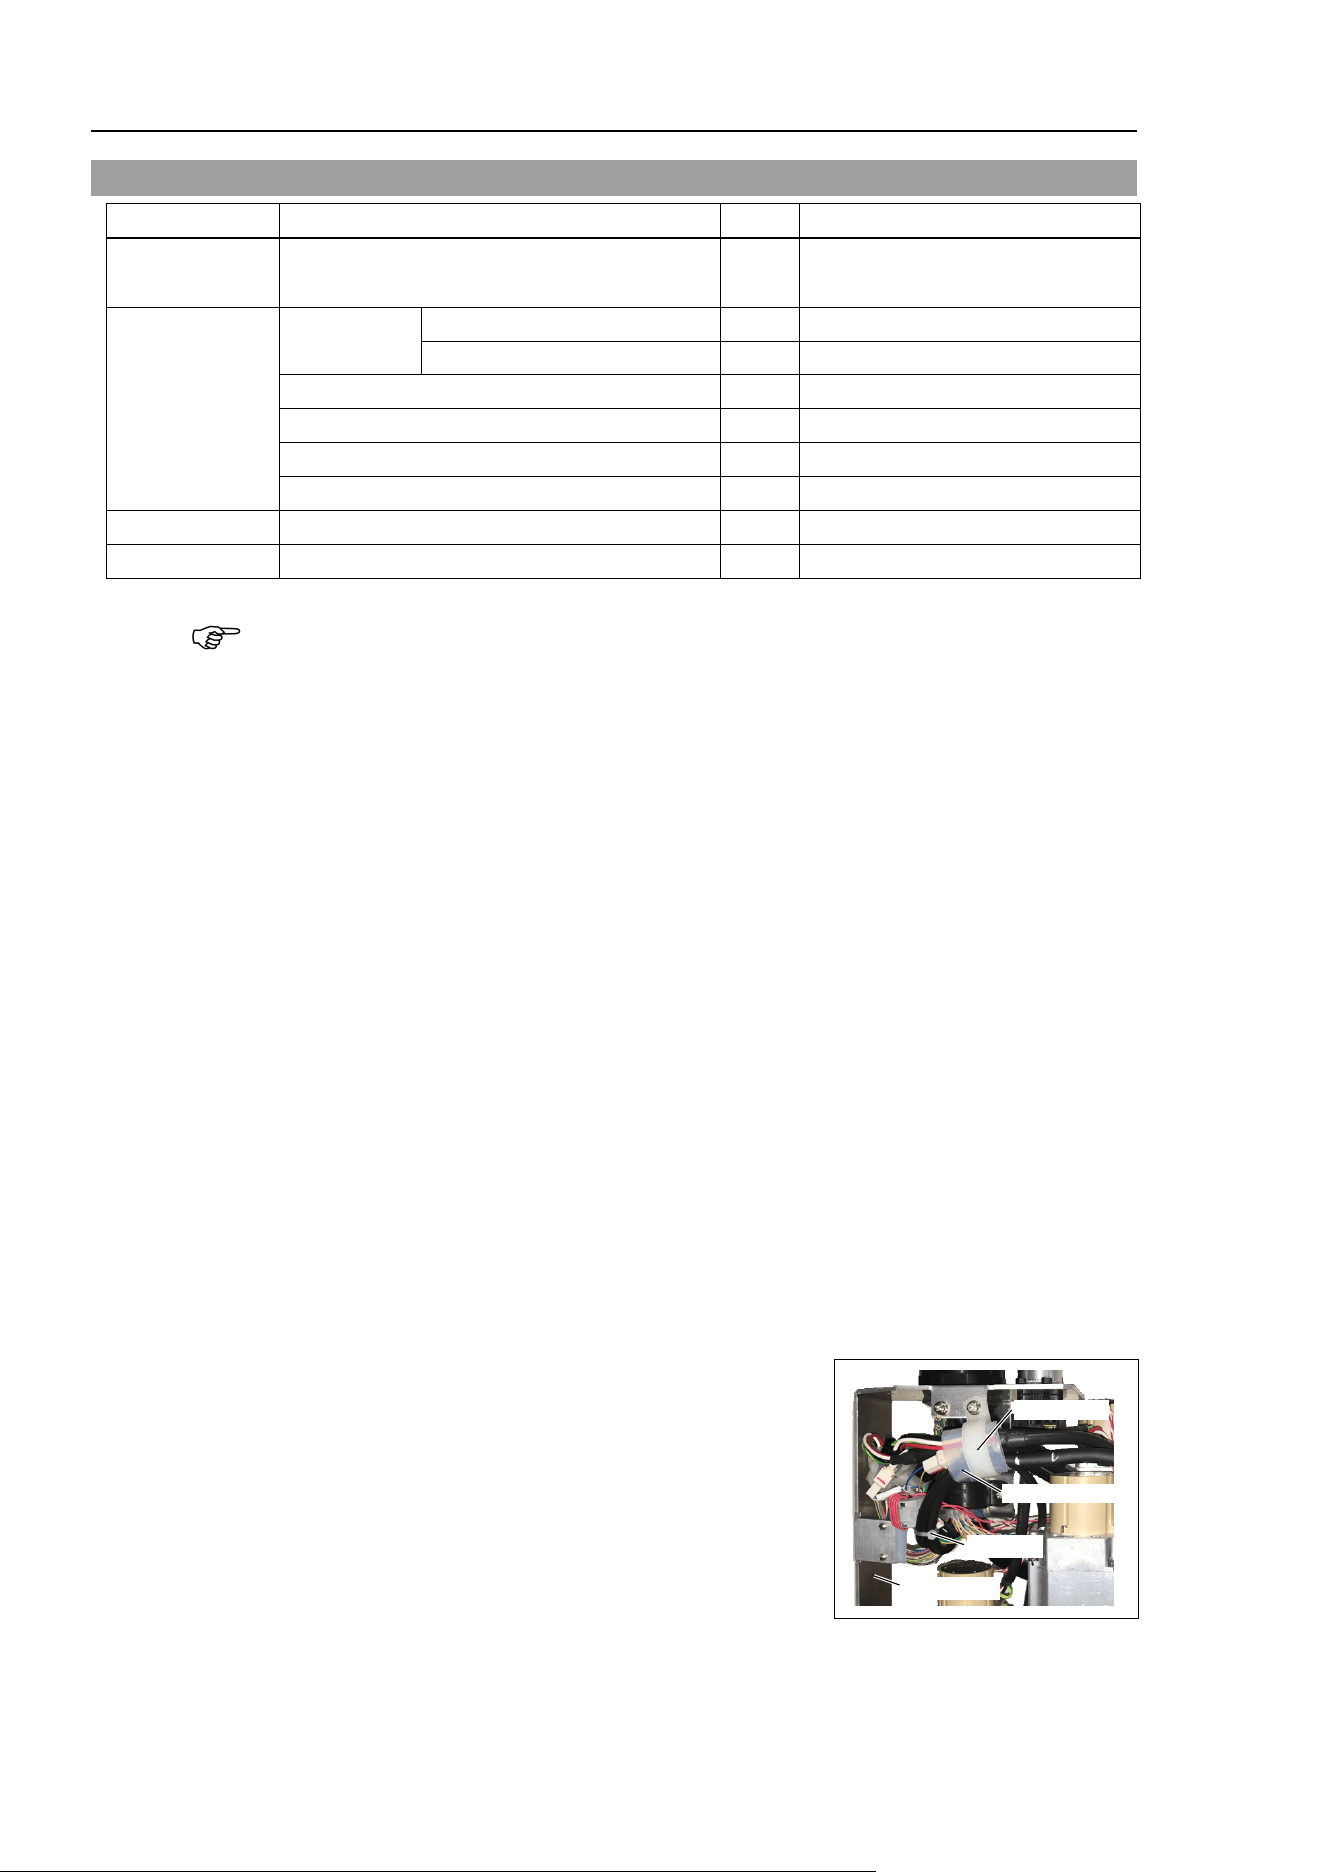
Maintenance 6. Joint #2
100 L
S20-B Rev.4
6.1 Replacing Joint #2 Motor
Name
Qty.
Note
Maintenance
Parts
AC Servo Motor (520 W) 1 2197985
Tools
Hexagonal
wrench
width across flats: 2.5 mm
1
For M5 set screw
width across flats: 4 mm
1
For M5 screw
Cross-point screwdriver (#2)
1
For M4 screw
Torque wrench
1
Nippers
1
For cutting wire tie
Wiping cloth
1
For wiping grease
Material
Wire tie
-
Grease
Grease (SK-1A)
-
A brake is mounted on the motor of Joints #3 and #4 to prevent the shaft from moving down
and rotating due to the weight of the end effector while the power to the Controller is OFF
or while the motor is in OFF status (MOTOR OFF).
Move the shaft down to its lower limit before the replacement procedure following the
removal steps.
Joint #2
Motor
Removal
(1)
Turn ON the Controller.
(2)
Push down the shaft to its lower limit while pre
ssing the brake release switch.
Be sure to keep enough space and prevent
the end effector hitting any
peripheral
equipment.
The brake release switch is applied to both Joints #3 and Joint #4.
When the brake release switch is pressed, the respective brakes of the Joint #3 and Joint
#4
are released simultaneously.
Be careful of the
shaft falling and rotating while the brake release switch is
being
pressed
because the shaft may be lowered by the weight of an end effector.
(3)
Turn OFF the Controller.
(4)
Remove the
Arm Top Cover.
For details, refer to Maintenance: 3.1 Arm Top Cover.
(5)
Remove the User Plate
and Duct Plate.
For details, refer to Maintenance: 3 Covers.
(6)
Remove the Clip Band and Sheet binding the
motor
cables.
The Clip Band and sheet will be reused
when
installing the cable unit.
Be careful not to lose them.
D
o not cut the wire tie (in the duct fittings outlet) that
binds the cables to the duct
plate.
Clip Band
Wire Tie
Duct Plate
Silicon Sheet
(7)
Disconnect the following connectors
.
Connectors: X221, X42 (Hold the clip to remove.)
NOTE
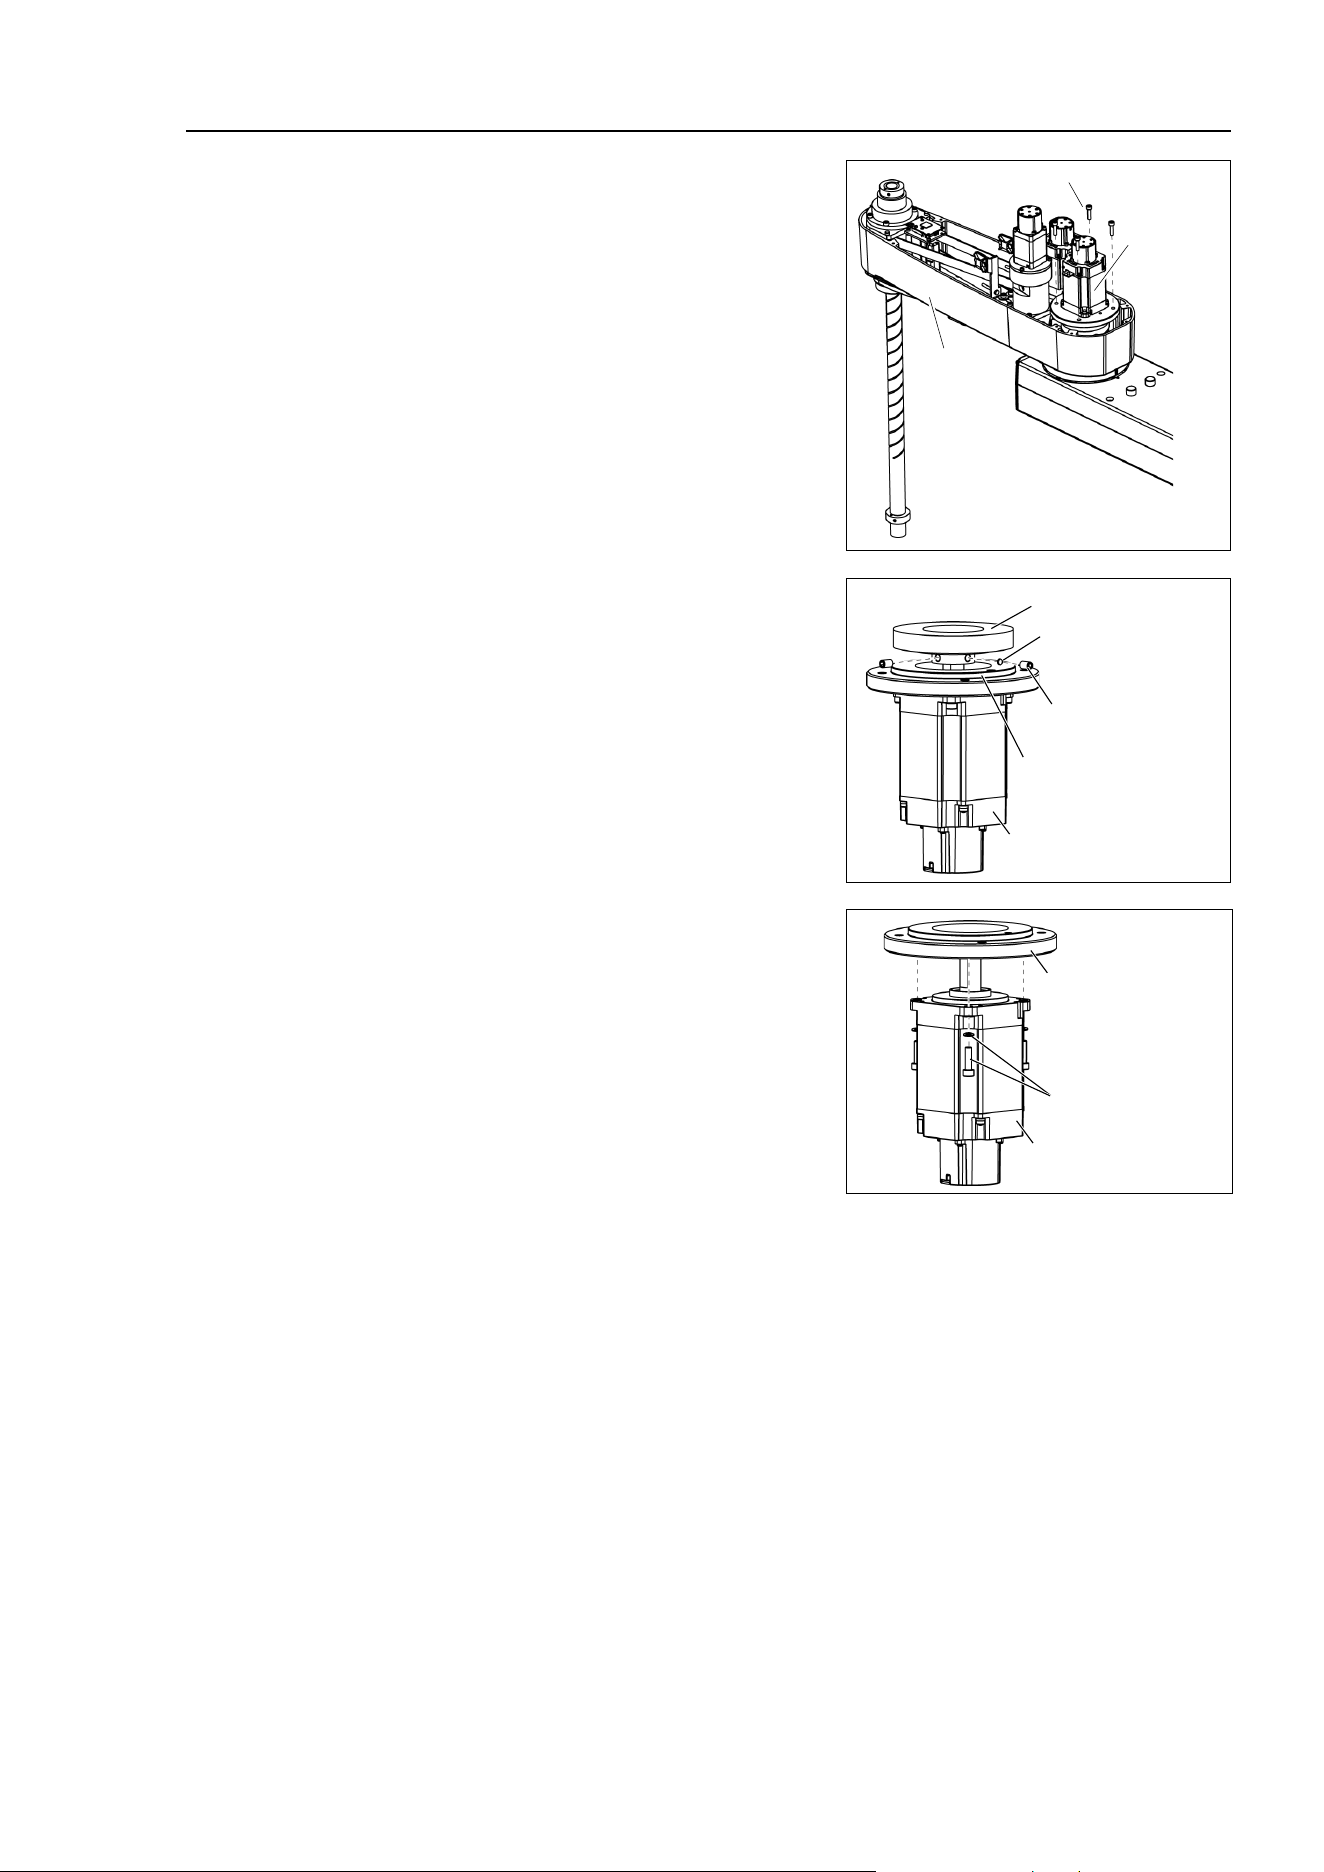
Maintenance 6. Joint #2
L
S20-B Rev.4 101
(8)
Remove the screws mounting the motor
unit and then remove the Joint #2 motor
unit from the Arm #2.
To pull out
the motor smoothly, move the
Arm #2 slowly by
hand while pulling the
motor
.
Joint #2
Motor Unit
Arm #2
4-M5×20
(9)
Remove
the waveform generator from the
Joint #2 motor.
There is a brass bushing in one of the
set
screw holes.
Be sure to keep the bushing.
The O ring will be used again.
Be
careful not to lose it.
2-M5×8
Set Screw
M5 Brass Bushing
Waveform Generator
O-ring
Joint #2 Motor
(10)
Remove the motor flange from the Joint #2
motor.
4-M4×15
+Plain Washer
Joint #2 Motor
Motor Flange
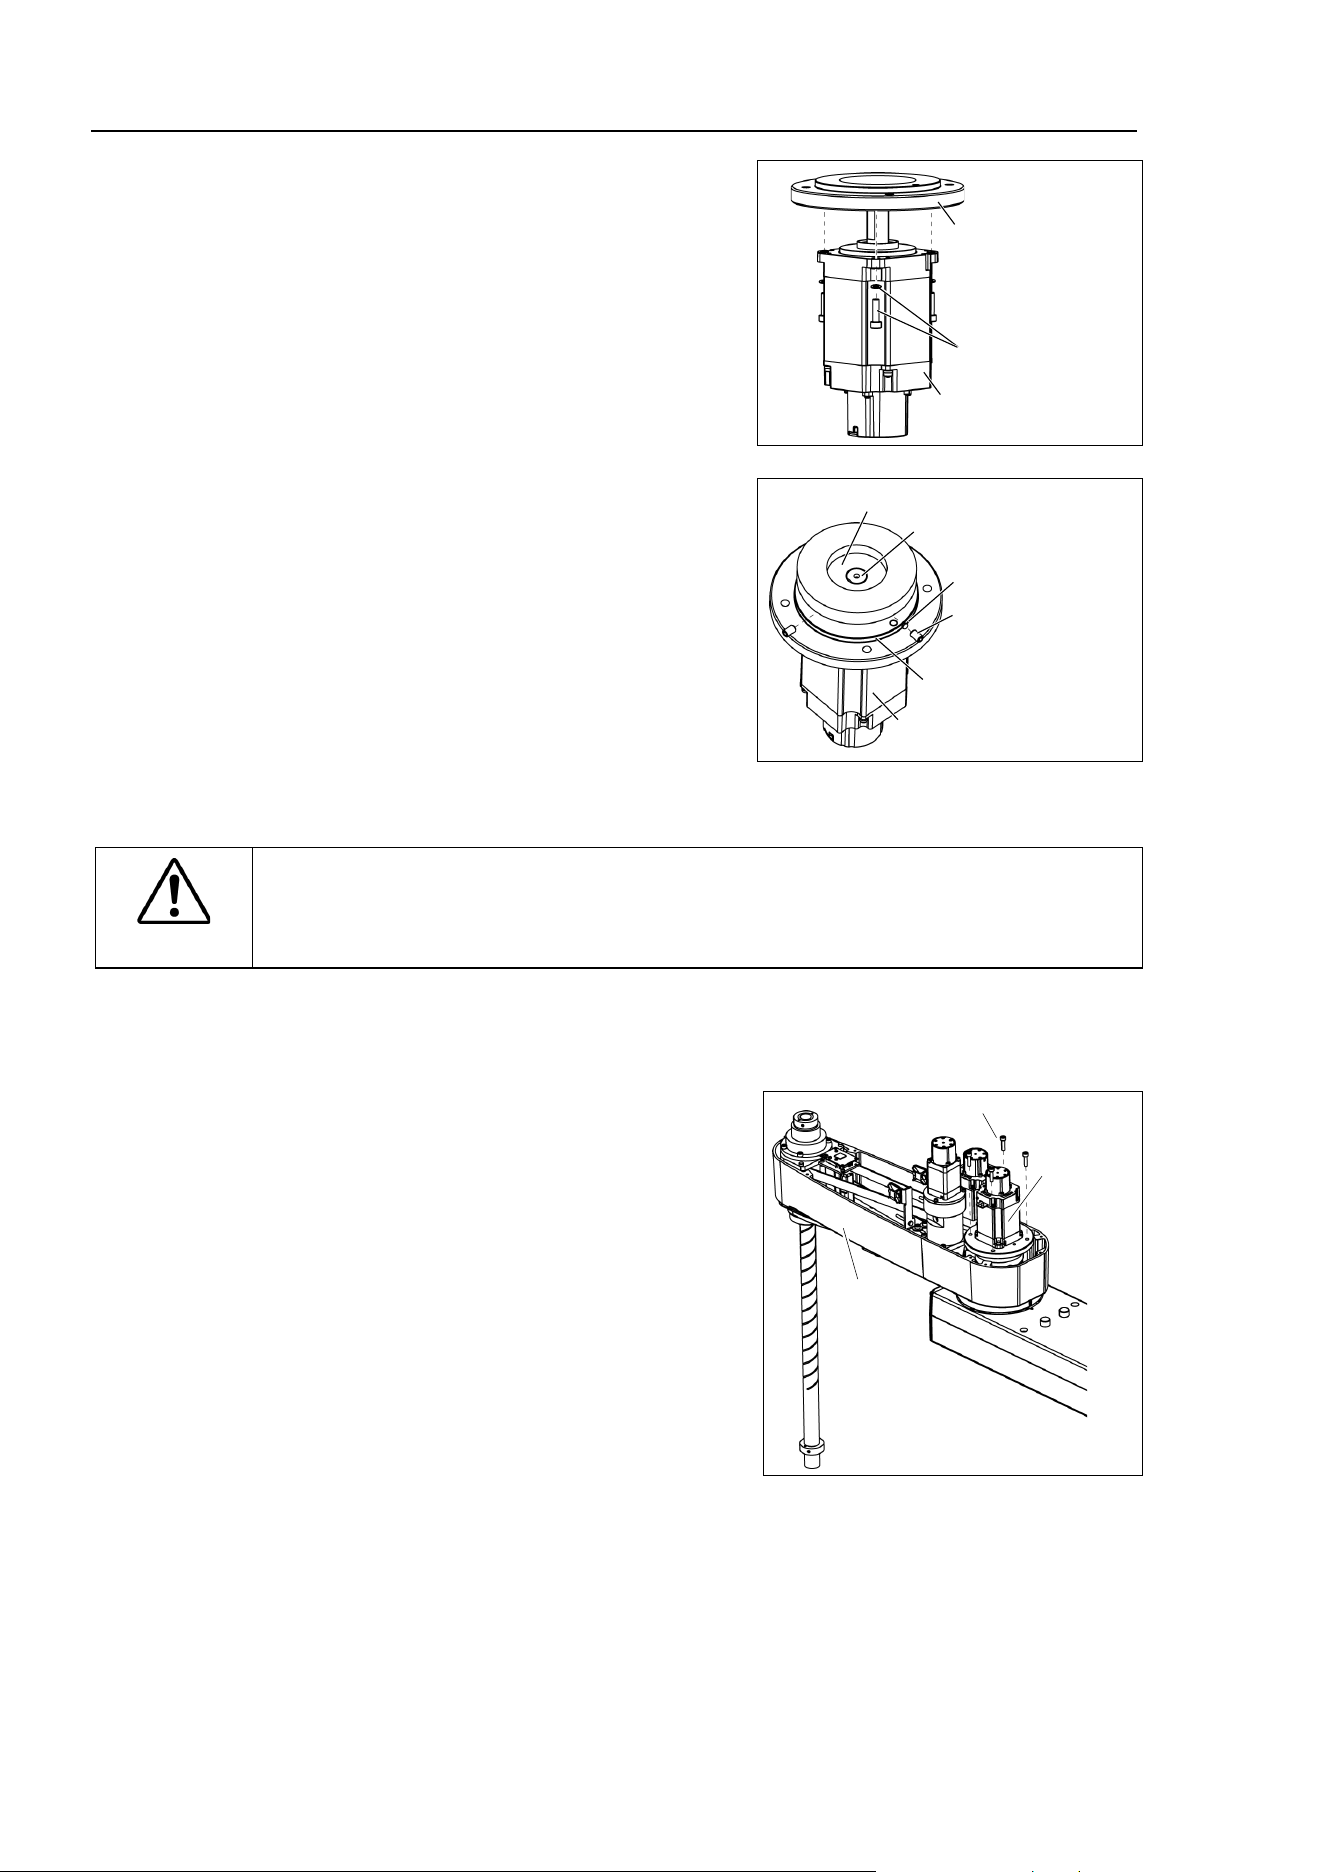
Maintenance 6. Joint #2
102 L
S20-B Rev.4
Joint #2 Motor
Installation
(1)
Mount
the motor flange on the Joint #2
motor.
4-M4×15
+ Plain Washer
Joint #2 Motor
Motor Flange
(2)
Mount the waveform generator on the Joint
#2 motor.
Be sure to
align the end face of the
waveform
generator to the end face of the
motor
shaft.
Tighten one of the set
screws vertically on
the
flat face of the motor shaft. Insert a
bushing
into the other set screw hole to
prevent
damage to the motor shaft.
2-M5×8
Set Screw
M5 Brass Bushing
End face of Waveform Generator
O-ring
Joint #2 Motor
End face of Motor shaft
CAUTION
■
See the figures above for the orientation of the
waveform generator. Be sure to
install the waveform generator properly.
Improper installation of the waveform
generator will result in improper function of the Manipulator.
(3)
Apply grease between the waveform generator and motor flange.
G
rease volume: 38 g (SK-1A)
(4)
M
ount the Joint #2 motor unit on the Arm #2.
To insert the motor, slowly move the Arm #2
by hand and push in.
Joint #2
Motor Unit
Arm #2
4-M5×20
(5)
Mount the User Plate
and Duct Plate.
For details, refer to Maintenance: 3. Covers.
(6)
Connect the following connectors
.
Connectors: X221, X42
Maintenance 6. Joint #2
L
S20-B Rev.4 103
(7)
Install the clip
band removed in the removal step (6), bind the cables, and then fix
them.
Do not allow unnecessary strain on the cables.
(8)
Mount the Arm Top Cover.
F
or details, refer to Maintenance: 3.1 Arm Top Cover.
(9)
Check if the Joint #2 moves in a Jog
motion by operating from EPSON RC+ menu
-
[Tools]
-[Robot Manager]-[Jog & Teach].
If the Manipulator oscillates with MotorON and the following errors are detected,
E
rror 5041: Motor torque output failure in low power state.
Error 4241: Over speed during low power mode was detected.
or when the joint other than Joint #2 moves, the connector for the other joint might be
connected to the Joint #2 motor.
Check the connector connection.
(10)
Execute the calibration for Joint #2.
F
or details refer to Maintenance: 13. Calibration.
Maintenance 6. Joint #2
104 L
S20-B Rev.4
6.2 Replacing Joint #2 Reduction Gear Unit
A reduction gear unit consists of the following three parts. When replacing the reduction
gear unit, be sure to always replace the following parts all together as one set.
Waveform generator, Flexspline, Circular spline
For details of the three parts, refer to Maintenance: 14. Maintenance parts list.
Name
Qty.
Note
Maintenance
parts
Reduction Gear Unit 1 1798349
Tools
Hexagonal
wrench
width across flats: 2.5 mm
1
For M5 set screw
width across flats: 3 mm
1
For M4 screw
width across flats: 4 mm
1
For M5 screw
Cross-point screwdriver (#2)
For M4 screw
Torque wrench
1
Nippers
1
For cutting wire tie
Spatula
1
For apply grease
Wiping cloth
1
For wiping grease (Motor Flange)
1
For wiping grease (Bolt)
Material
Wire tie
-
Grease
Grease (SK-1A)
-
A brake is mounted on the motor of Joints #3 and #4 to prevent the shaft from moving down
and rotating due to the weight of the end effector while the power to the Controller is OFF
or while the motor is in OFF status (MOTOR OFF).
Move the shaft down to its lower limit before the replacement procedure following the
removal steps.
NOTE
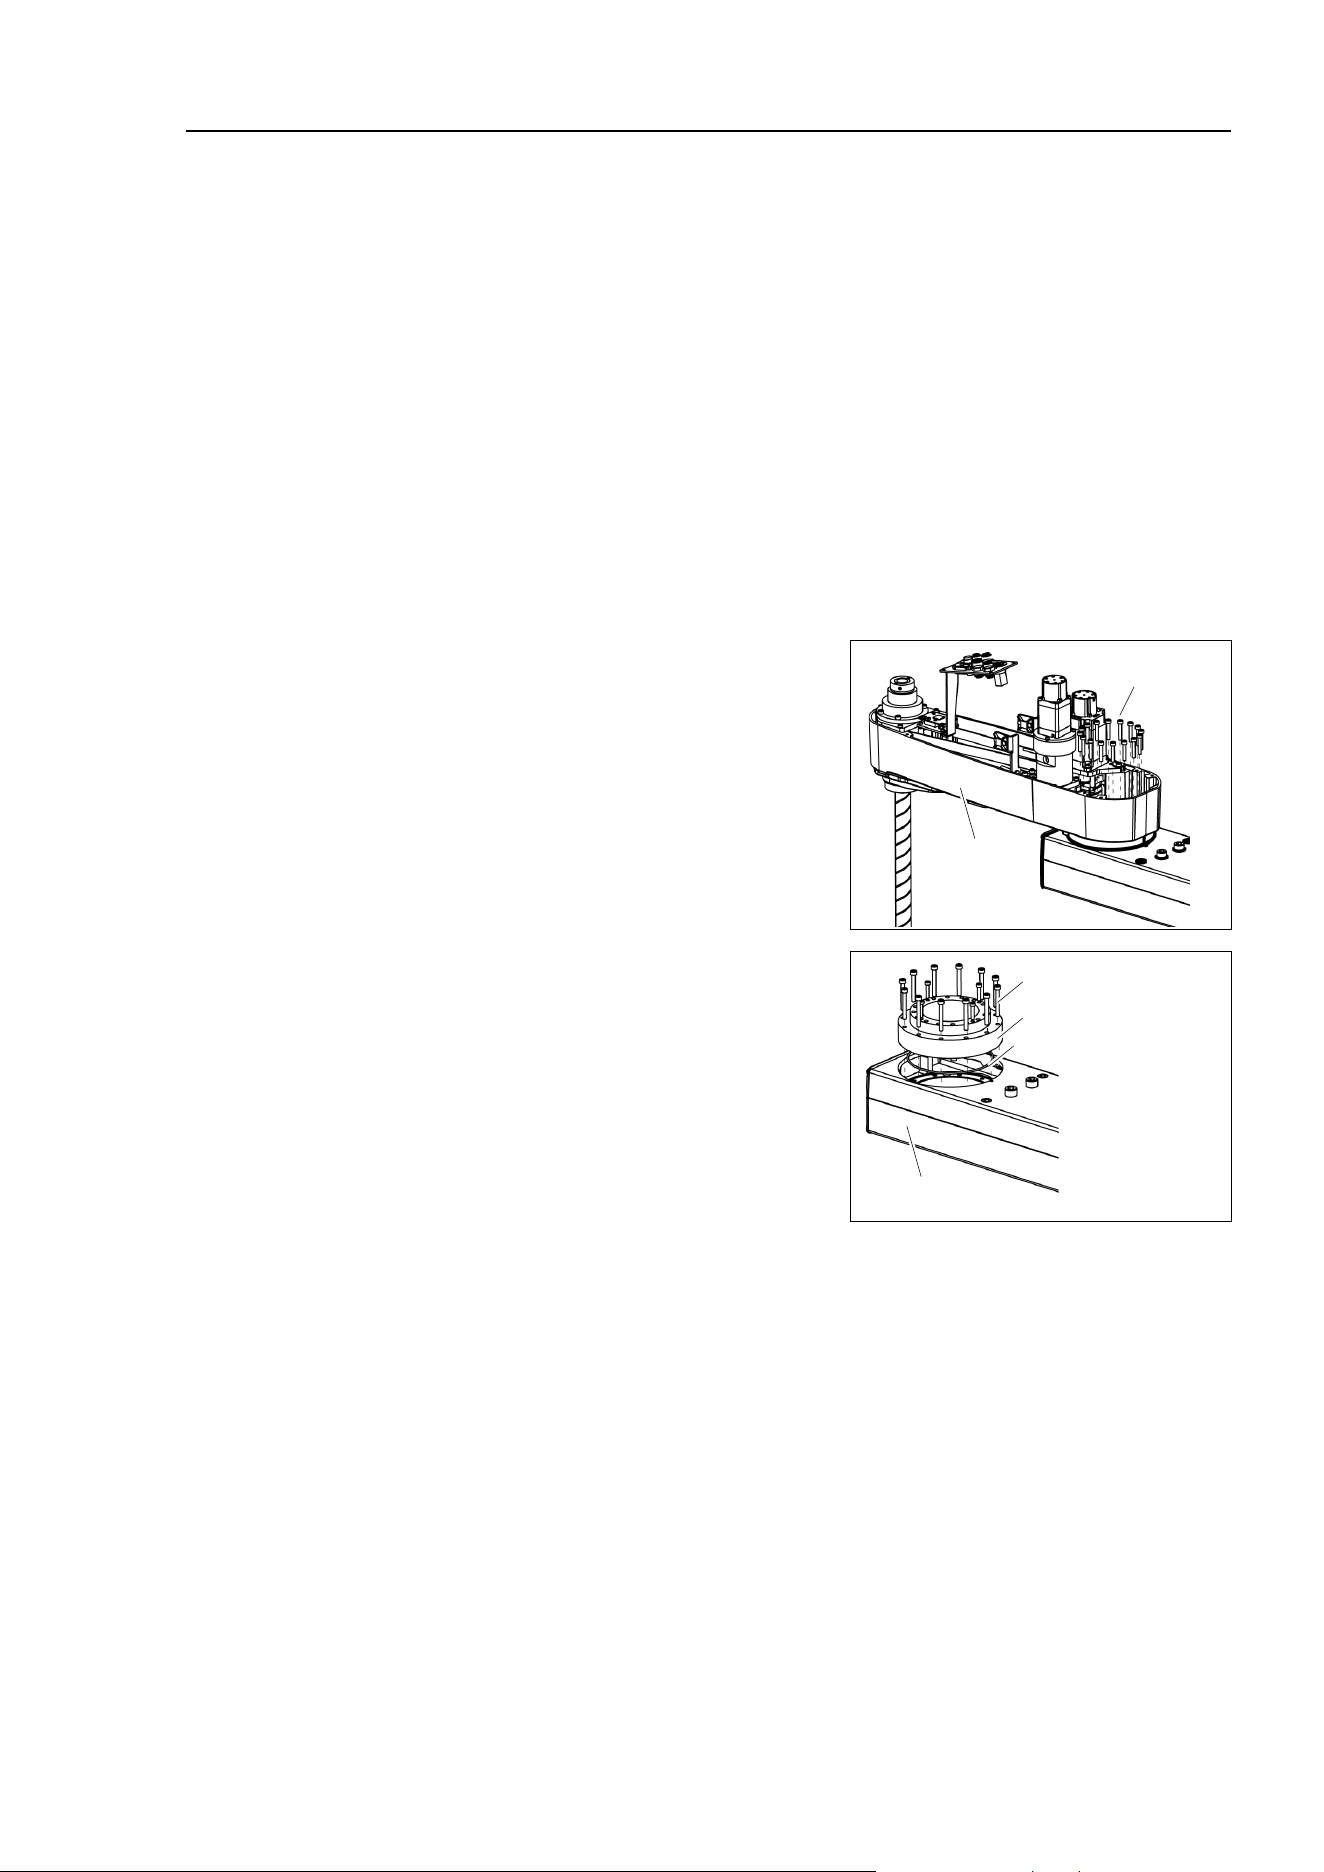
Maintenance 6. Joint #2
LS20-B Rev.4 105
Joint #2
R
eduction
G
ear Unit
Removal
(1)
Turn ON the Controller.
(2)
Push down the shaft to its lower limit while pressing the brake release switch.
Be sure to keep enough space and prevent the
end effector
hitting any peripheral
equipment.
The brake release switch is applied to both Joints #3 and Joint #4.
When the brake release switch is pressed, the respective brakes of the Joint #3 and Joint
#4 are
released simultaneously.
Be careful of the
shaft falling and rotating while the brake release switch is
being
pressed
because the shaft may be lowered by the weight of an end effector.
(3)
Turn OFF the Controller.
(4)
Remove the waveform
generator from the Joint #2 motor.
Follow the removal steps in Maintenance: 6.1 Replacing Joint #2 Motor.
(5)
Remove the Arm #2 mounting screws to
remove it from the
reduction gear unit.
Arm #2
16-M5×30
(6)
Remove the
reduction gear unit from the
Arm #1 by removing the screws that
mounts the reduction gear unit on the Arm
#1.
There is an O
-ring between the Arm #1 and
the reduction gear unit.
Be careful not to lose the removed O
-ring.
Arm #1
12-M5×40
Reduction Gear Unit
O ring
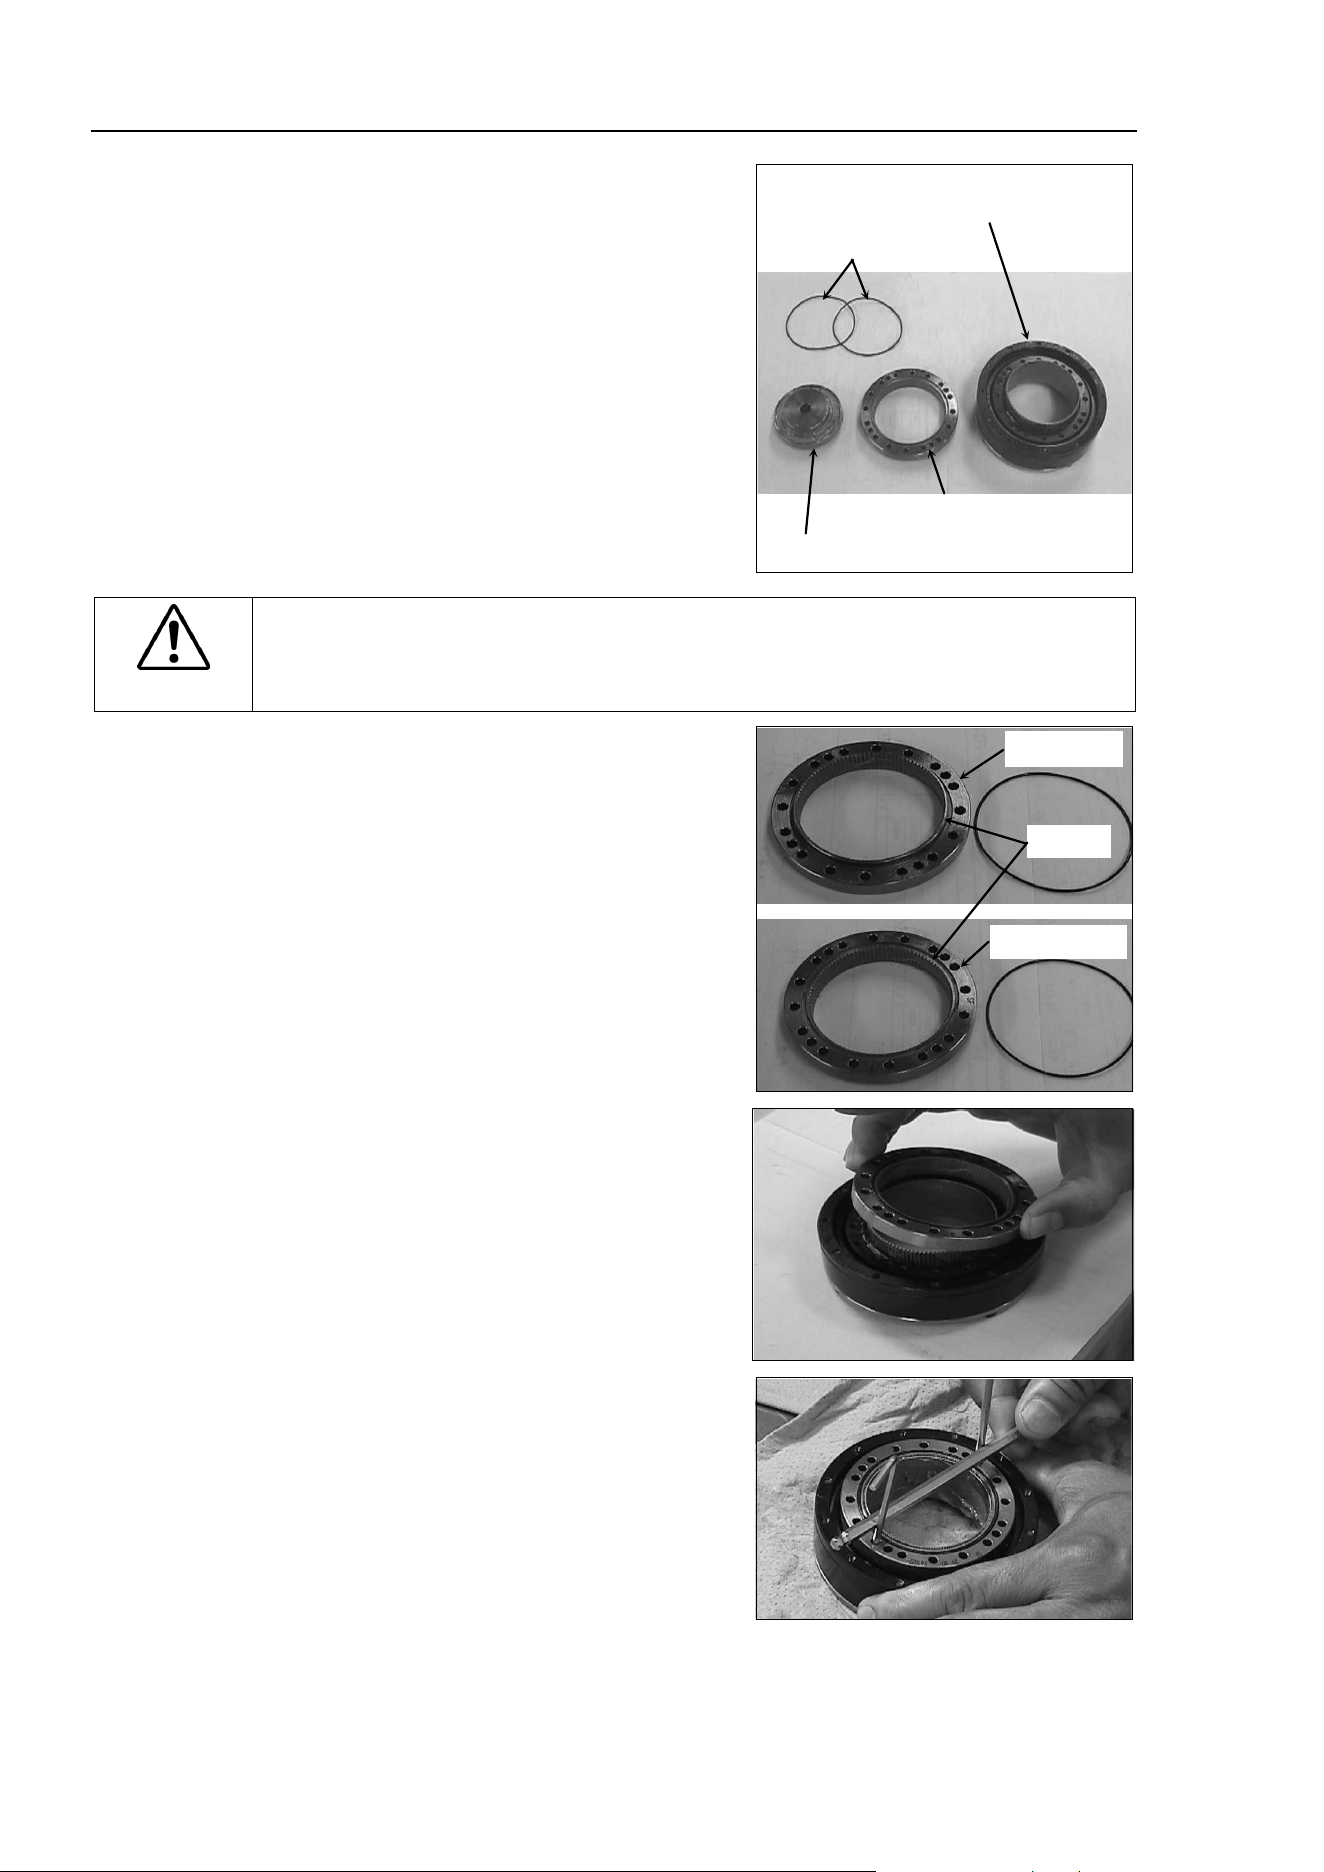
Maintenance 6. Joint #2
106 L
S20-B Rev.4
Joint #2
R
eduction
G
ear Unit
Installation
(1)
A
new
reduction gear unit contains the
parts shown
in the picture on the right
when it
is unpacked.
T
he gear grooves of the flexspline, circular
spline
, and the bearings of the waveform
generator
have been greased. Wipe off
excess grease
from the mounting surface.
O-ring
Flexspline and
Cross roller bearing unit
Circular spline
Waveform generator
C
AUTION
■
Never
adjust (loosen or tighten) the mounting bolts between the flexspline and
cross roller bearing unit.
If the mounting bolts are adjusted, the flexspline and
cross roller bearing unit must be
aligned by the maker of the reduction gear unit.
(2)
Fit the
O-rings into the grooves on both
side
s of the new circular spline.
Make
sure that the rings do not come out
of the grooves.
Convex side
Grooves
The other side
(3)
Face the convex side of the circular spline
down,
and then fit it into the flexspline.
If it is difficult to fit in, rotate the
circular
spline a little bit and change the position.
(4)
M
atch the screw holes on the inner ring of
the cross roller bearing unit and the
through holes of the circular spline.
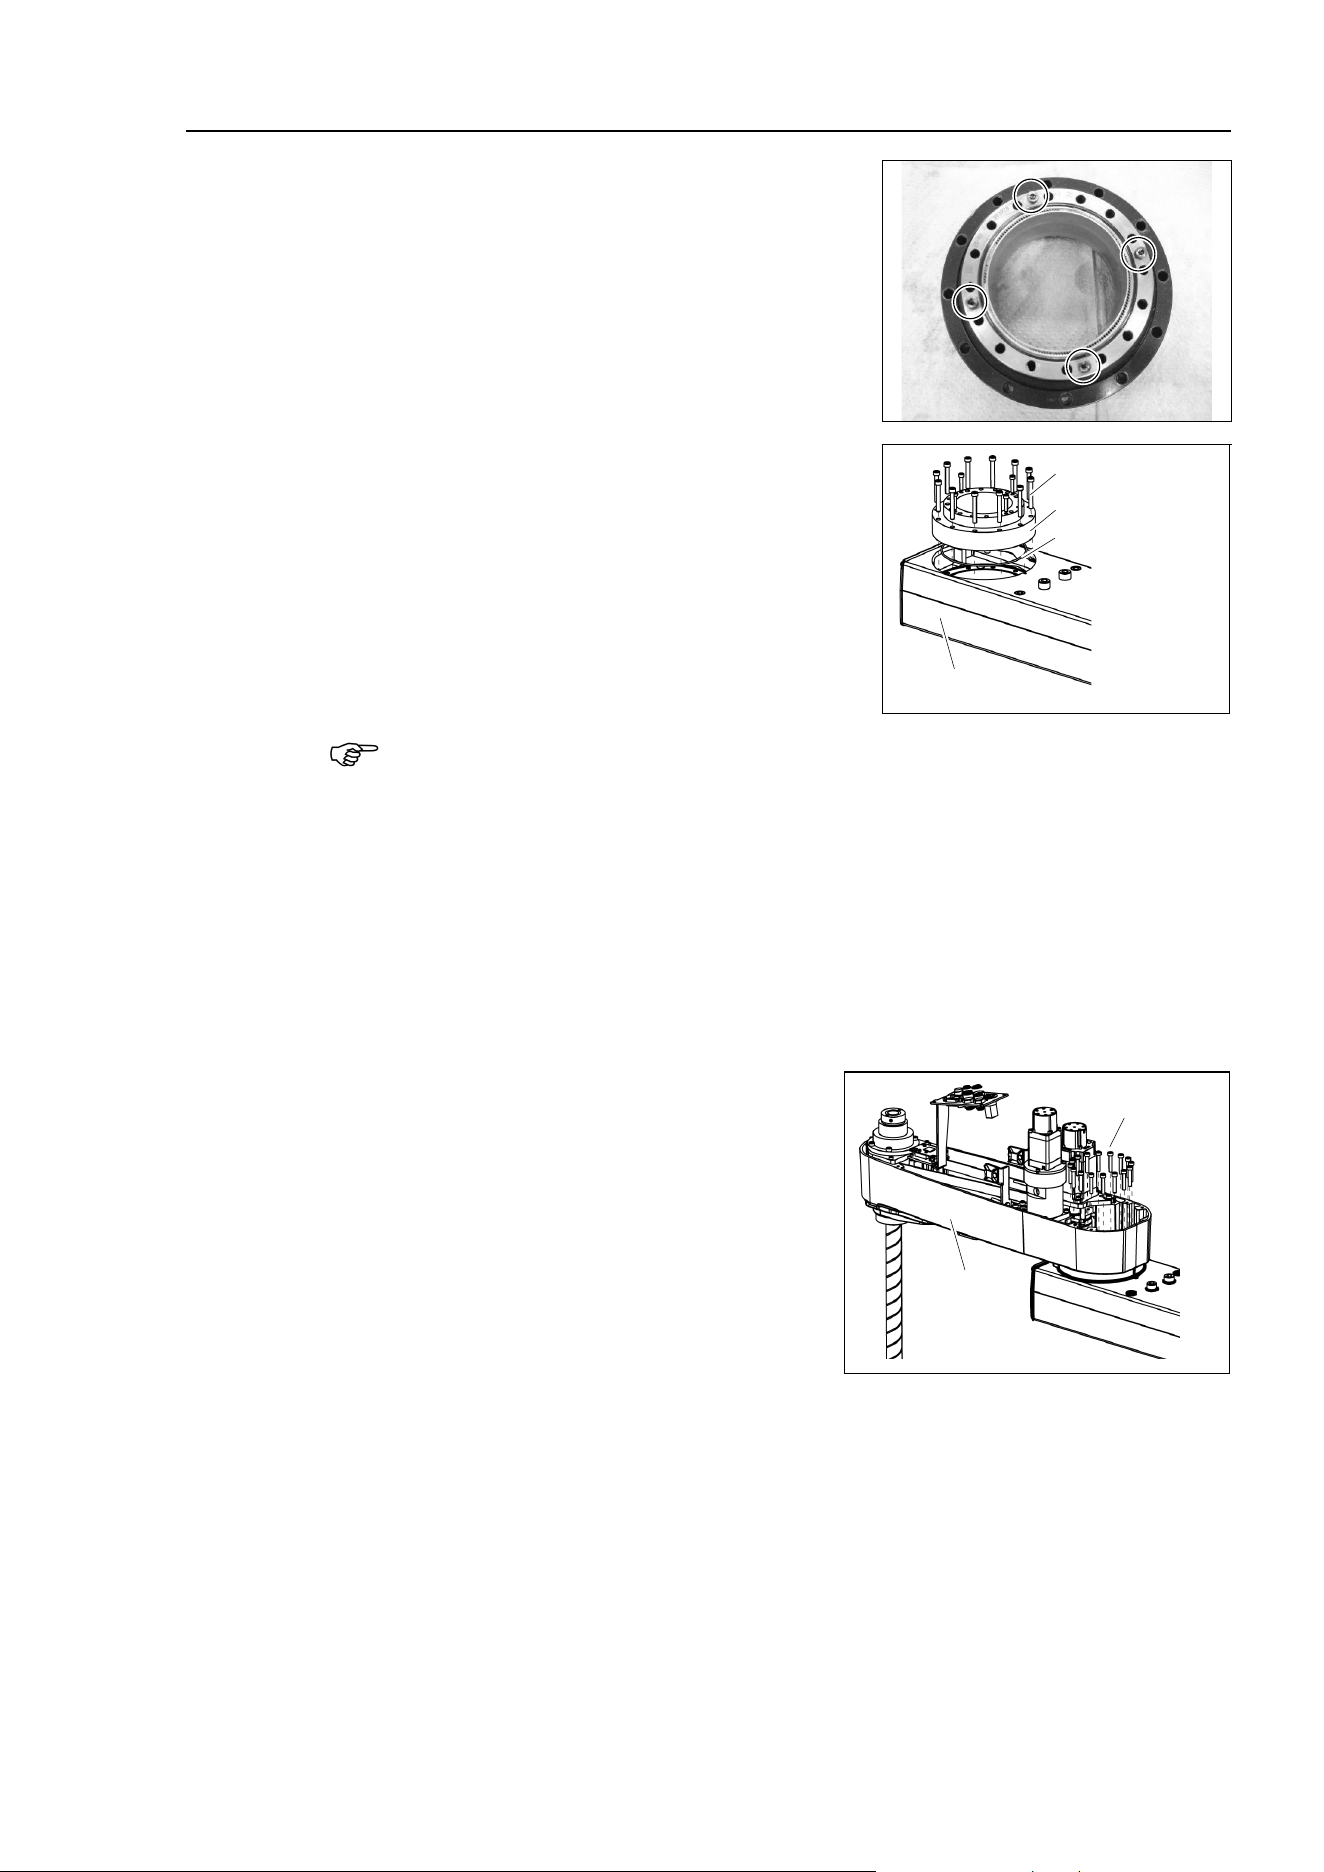
Maintenance 6. Joint #2
LS20-B Rev.4 107
(5)
Secure
the cross roller bearing to
the circular
spline
.
4-M4×20
Tightening torque: 4.0 N·m (40.8 kgf·cm)
(6)
Set the O-ring removed in the removal step (6)
into the O-ring groove of the Arm #1.
Install the reduction gear unit on the Arm #1.
Hexagon socket head cap bolts: 12-M5×40
Tightening torque: 10.0 N⋅m (102 kgf⋅cm)
Arm #1
12-M5×40
Reduction Gear
Unit
O-ring
Loosely secure all bolts in a crisscross pattern so that the bolts will be secured evenly.
Then, using a torque wrench, tighten each bolt securely in a crisscross pattern at the
torque specified in the
above.
(6)
Apply grease between the motor flange an
d waveform generator and next inside the
flexspline.
Between the motor flange and waveform generator:
Grease volume: 38 g (SK-1A)
Inside the flexspline:
Grease volume: 90 g (SK-1A)
(7)
Set the attached O-ring into the O-ring
groove of the circular spline.
Secure the Arm #2 on the reduction gear
unit.
Arm #2
16-M5×30
(8)
Mount and Joint #2 motor.
Follow the installation steps in Maintenance: 6.1 Replacing Joint #2 Motor.
NOTE
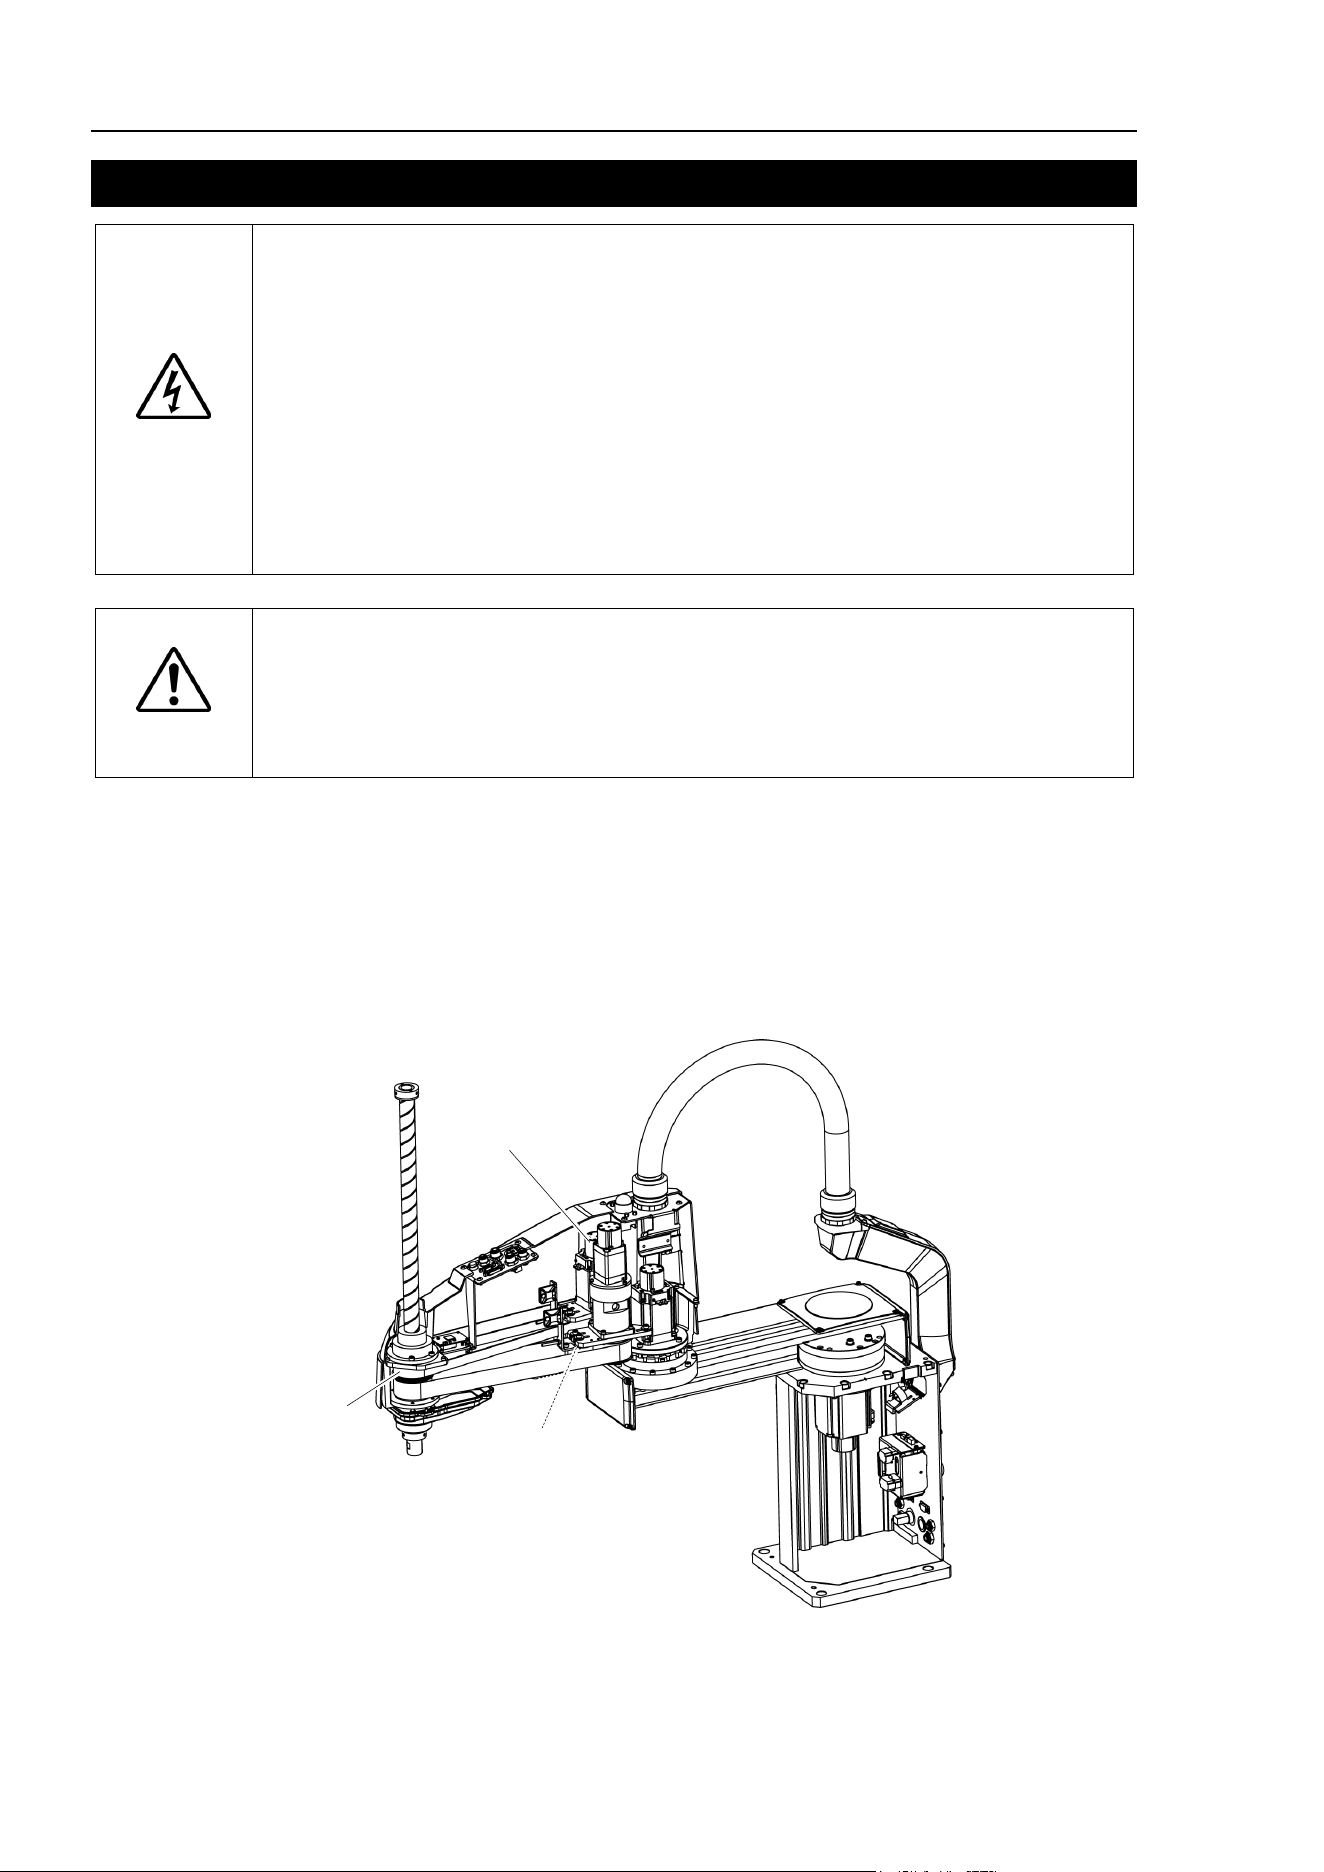
Maintenance 7. Joint #3
108 L
S20-B Rev.4
7. Joint #3
W
ARNING
■
Do not connect or disconnect the motor connectors while the power to the robot
system is turned ON. Connecting or disconnecting the motor connectors
with
the power ON is extremely hazardous and may result
in serious bodily injury as
the Manipulator may mo
ve abnormally, and also may result in electric shock
and/or malfunction of the robot system.
■
To shut off power to the robot system, disconnect the power plug from the power
source. Be sure to connect the AC power cable to a power receptacle.
DO NOT connect it directly to a factory power source.
■
Before performing any replacement procedure, turn OFF the Controller and
related equipment,
and then disconnect the power plug from the power source.
Performing any replacement procedure with the power ON is extremely hazardous
and may result in
electric shock and/or malfunction of the robot system.
C
AUTION
■
Be careful not to apply excessive shock to the motor shaft when replacing
the
motor
s. The shock may shorten the life cycle of the motors and encoder and/or
damage them.
■
Never disassemble the motor and encoder. A disassembled motor and encoder
will cause a positional gap and cannot be used
again.
After parts have been replaced (motors, reduction gear units, brakes, timing belts, ball screw
spline unit, etc.), the Manipulator cannot operate properly because a mismatch exists
between the origin stored in each motor and its corresponding origin stored in the Controller.
After replacing the parts, it is necessary to match these origins.
The process of aligning the two origins is called “Calibration”.
Refer to Maintenance: 13. Calibration to execute the calibration.
Joint #3 Motor
Z belt
Joint #3 Brake
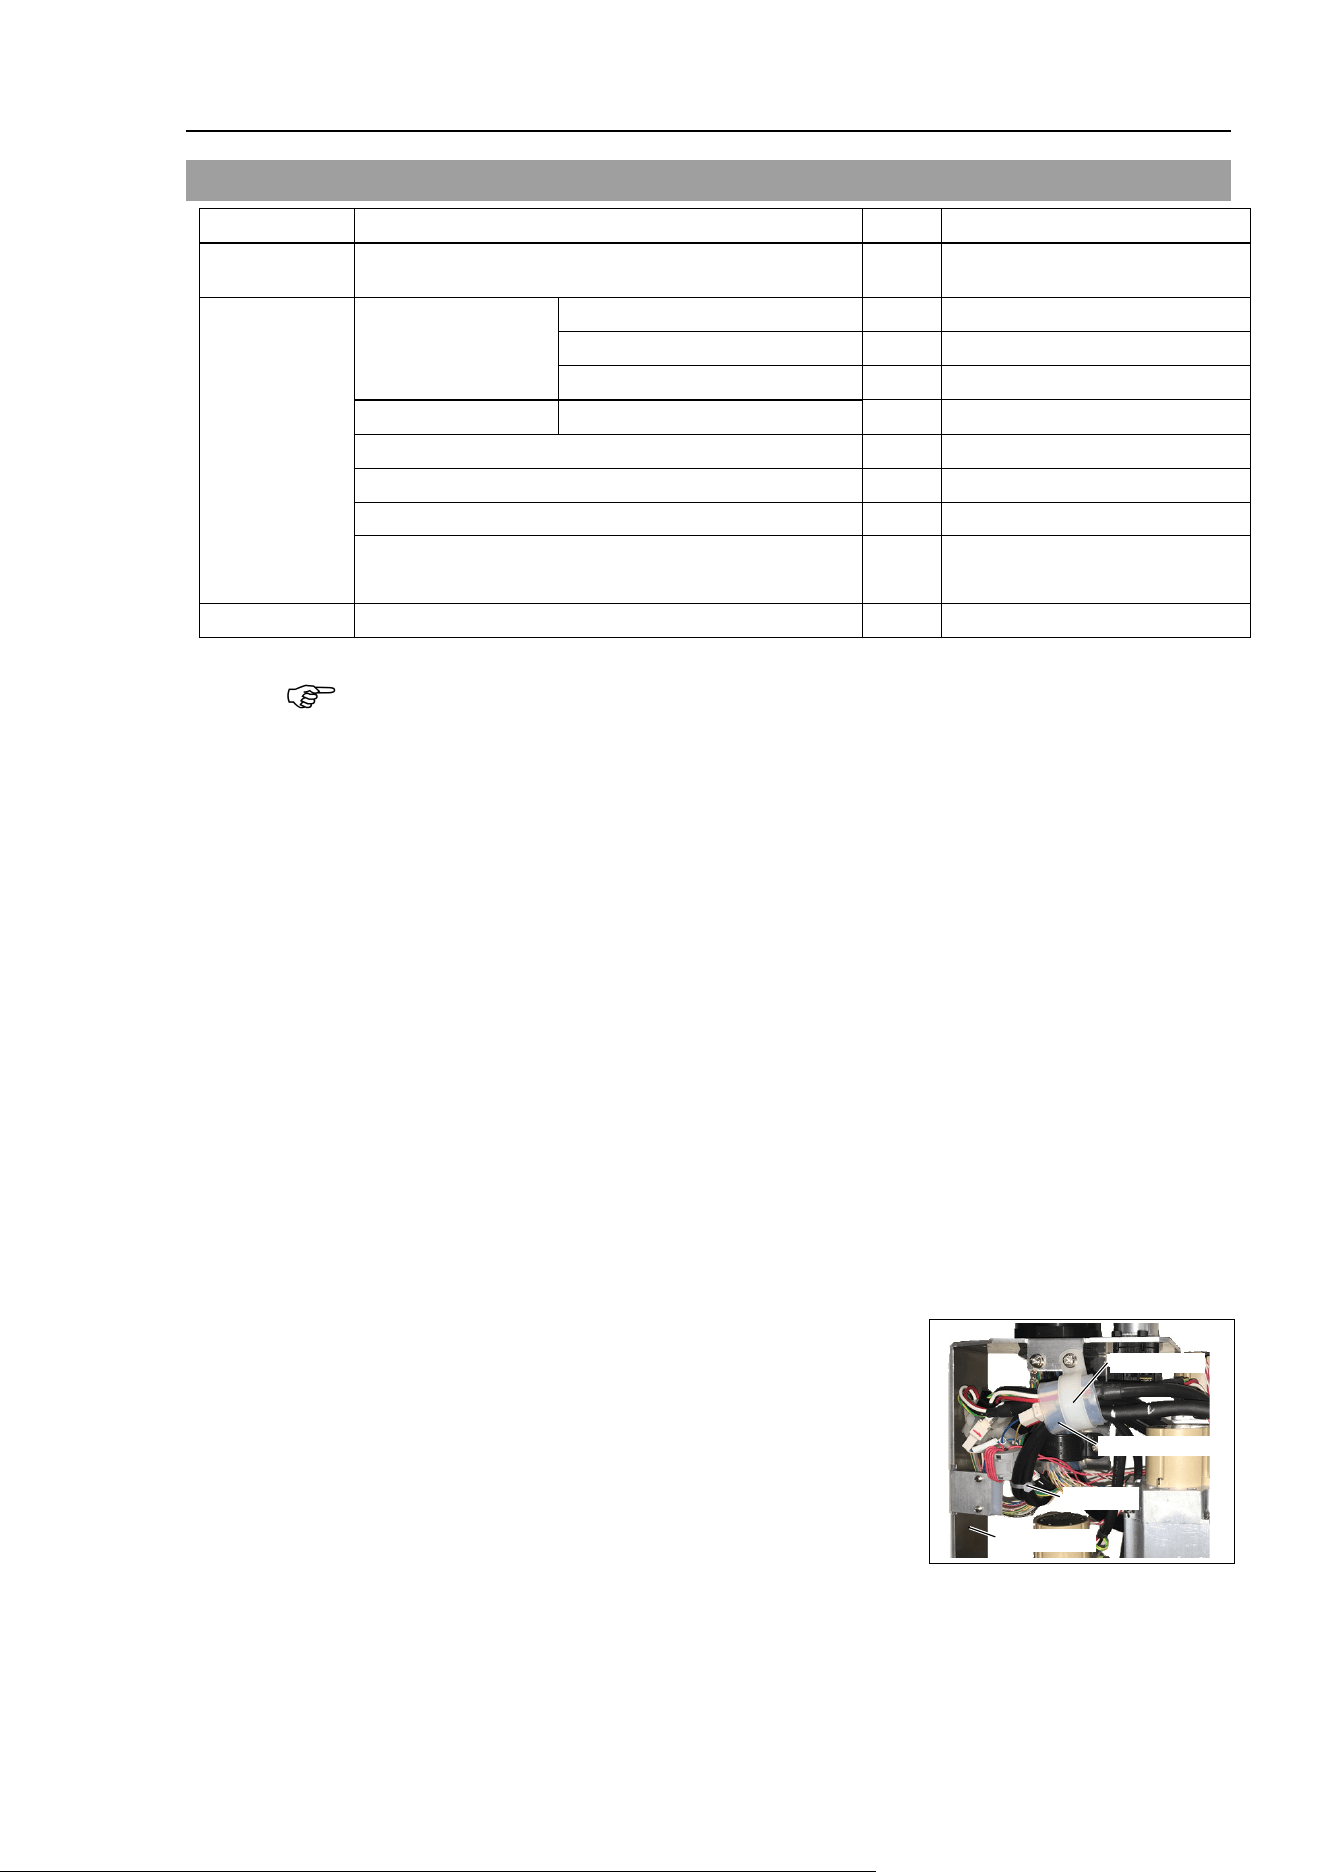
Maintenance 7. Joint #3
LS20-B Rev.4 109
7.1 Replacing Joint #3 Motor
Name
Qty.
Note
Maintenance
part
AC Servo Motor 520W 1 2197985
Tools
Hexagonal
wrench
width across flats: 2 mm
1
For M4 set screw
width across flats: 3 mm
1
For M4 screw
width across flats: 4 mm
1
For M5 screw
Spanner
width across flats: 7 mm
For M4 bolt, M4 nut
Cross-point screwdriver (#2)
For M3, M4 screw
Torque wrench
Nippers
1
For cutting wire tie
Sonic tension meter 1
Z: Belt tension
93N (9.5 ± 0.75 kgf)
Material
Wire tie
-
A brake is mounted on the motor of Joints #3 and #4 to prevent the shaft from moving down
and rotating due to the weight of the end effector while the power to the Controller is OFF
or while the motor is in OFF status (MOTOR OFF).
Move the shaft down to its lower limit before the replacement procedure following the
removal steps.
Joint #3 motor
Removal
(1)
Turn ON the Controller.
(2)
Push down the shaft to its lower limit while pressing the brake release switch. Be sure
to keep enough space and prevent
the end effector hitting any peripheral equipment.
The brake release switch is applied to both Joints #3 and Joint #4.
When the brake release switch is pressed, the respective brakes of the Joint #3 and
Joint #4 are released simultaneously.
Be careful of the
shaft falling and rotating while the brake release switch is being
pressed
because the shaft may be lowered by the weight of an end effector.
(3)
Turn OFF the Controller.
(4)
Remove the
Arm Top Cover.
For details, refer to Maintenance: 3.1 Arm Top Cover.
(5)
Remove the Clip Band
and Sheet binding the motor
cables.
Removed parts
will be used again. Be careful not
to lose them.
D
o not cut the wire tie (in the duct fittings outlet) that
binds the cables
to the duct plate.
Clip Band
Wire Tie
Duct Plate
Silicon Sheet
(6)
Remove
the User Plate and the Duct Plate.
For details, refer to Maintenance 3. Covers.
NOTE
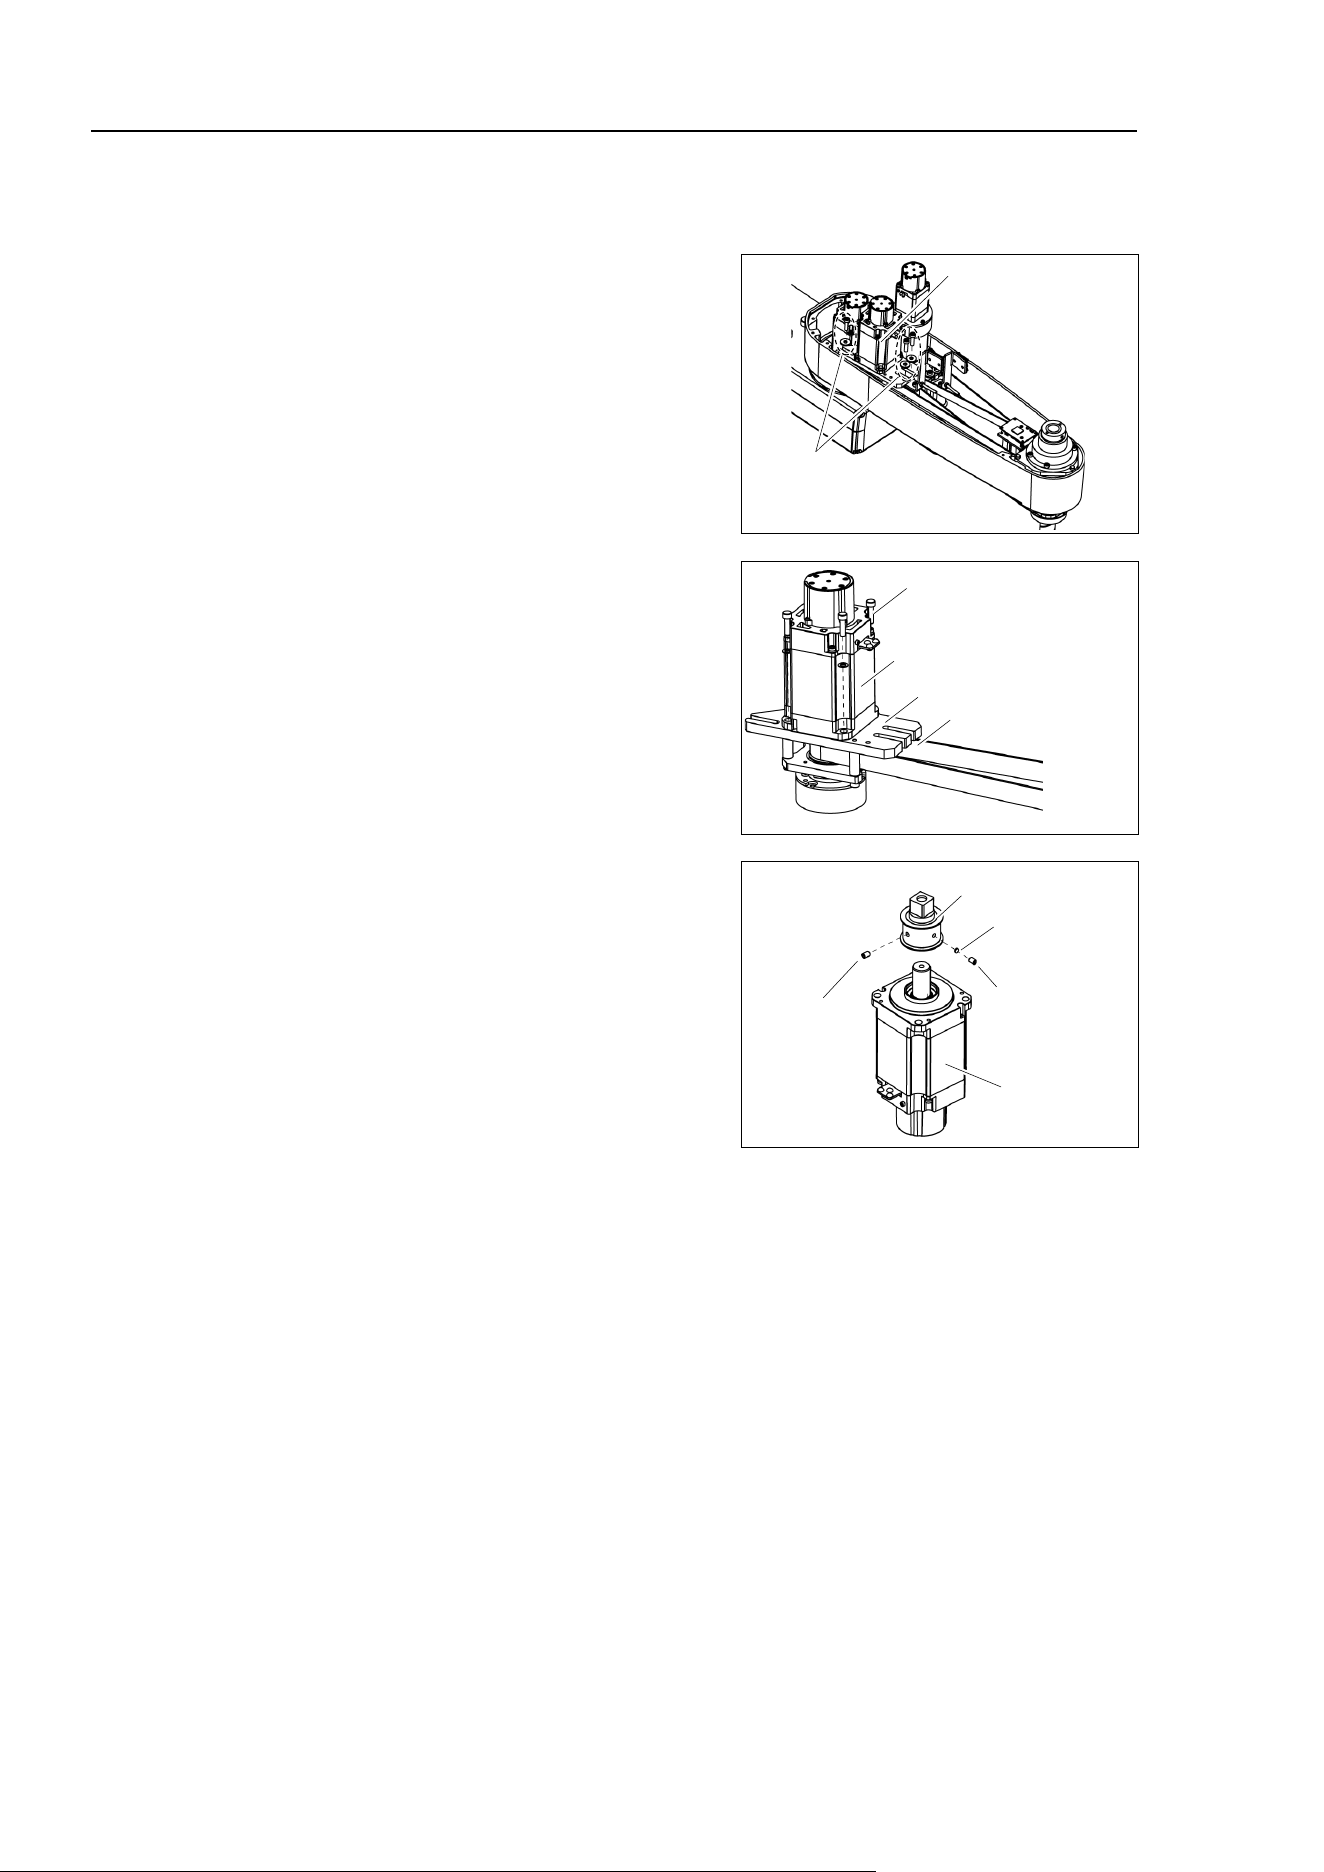
Maintenance 7. Joint #3
11
0 LS20-B Rev.4
(7)
Disconnect the following connectors.
C
onnectors: X231, X43 (Hold the clip to remove.)
(8)
Remove the bolts fixing the Joint #3 motor
unit.
The washers for slotted holes will be used
again
when installing the Z belt.
Be careful not to
lose them.
Joint #3
Motor Unit
3-M5×20
+ washer for
slotted hole
(
9)
Remove the Joint #3 motor from the Motor
P
late.
The belt is placed around the pulley.
To
remove the Joint #3 motor, tilt the motor
slightly
and pull it upward while avoiding
the belt.
Joint #3 Motor
Z belt
4-M4×15+ Plain washer
Motor Plate
(
10)
Loosen the screws of the pulley remove it
from the Joint #3 motor.
There is a brass bushing in one of the
set
screw
holes. Be sure to keep the
bushing.
Joint #3
Motor
M4 Bushing
Pulley
M6×6
Set Screw
M6×6
Set Screw
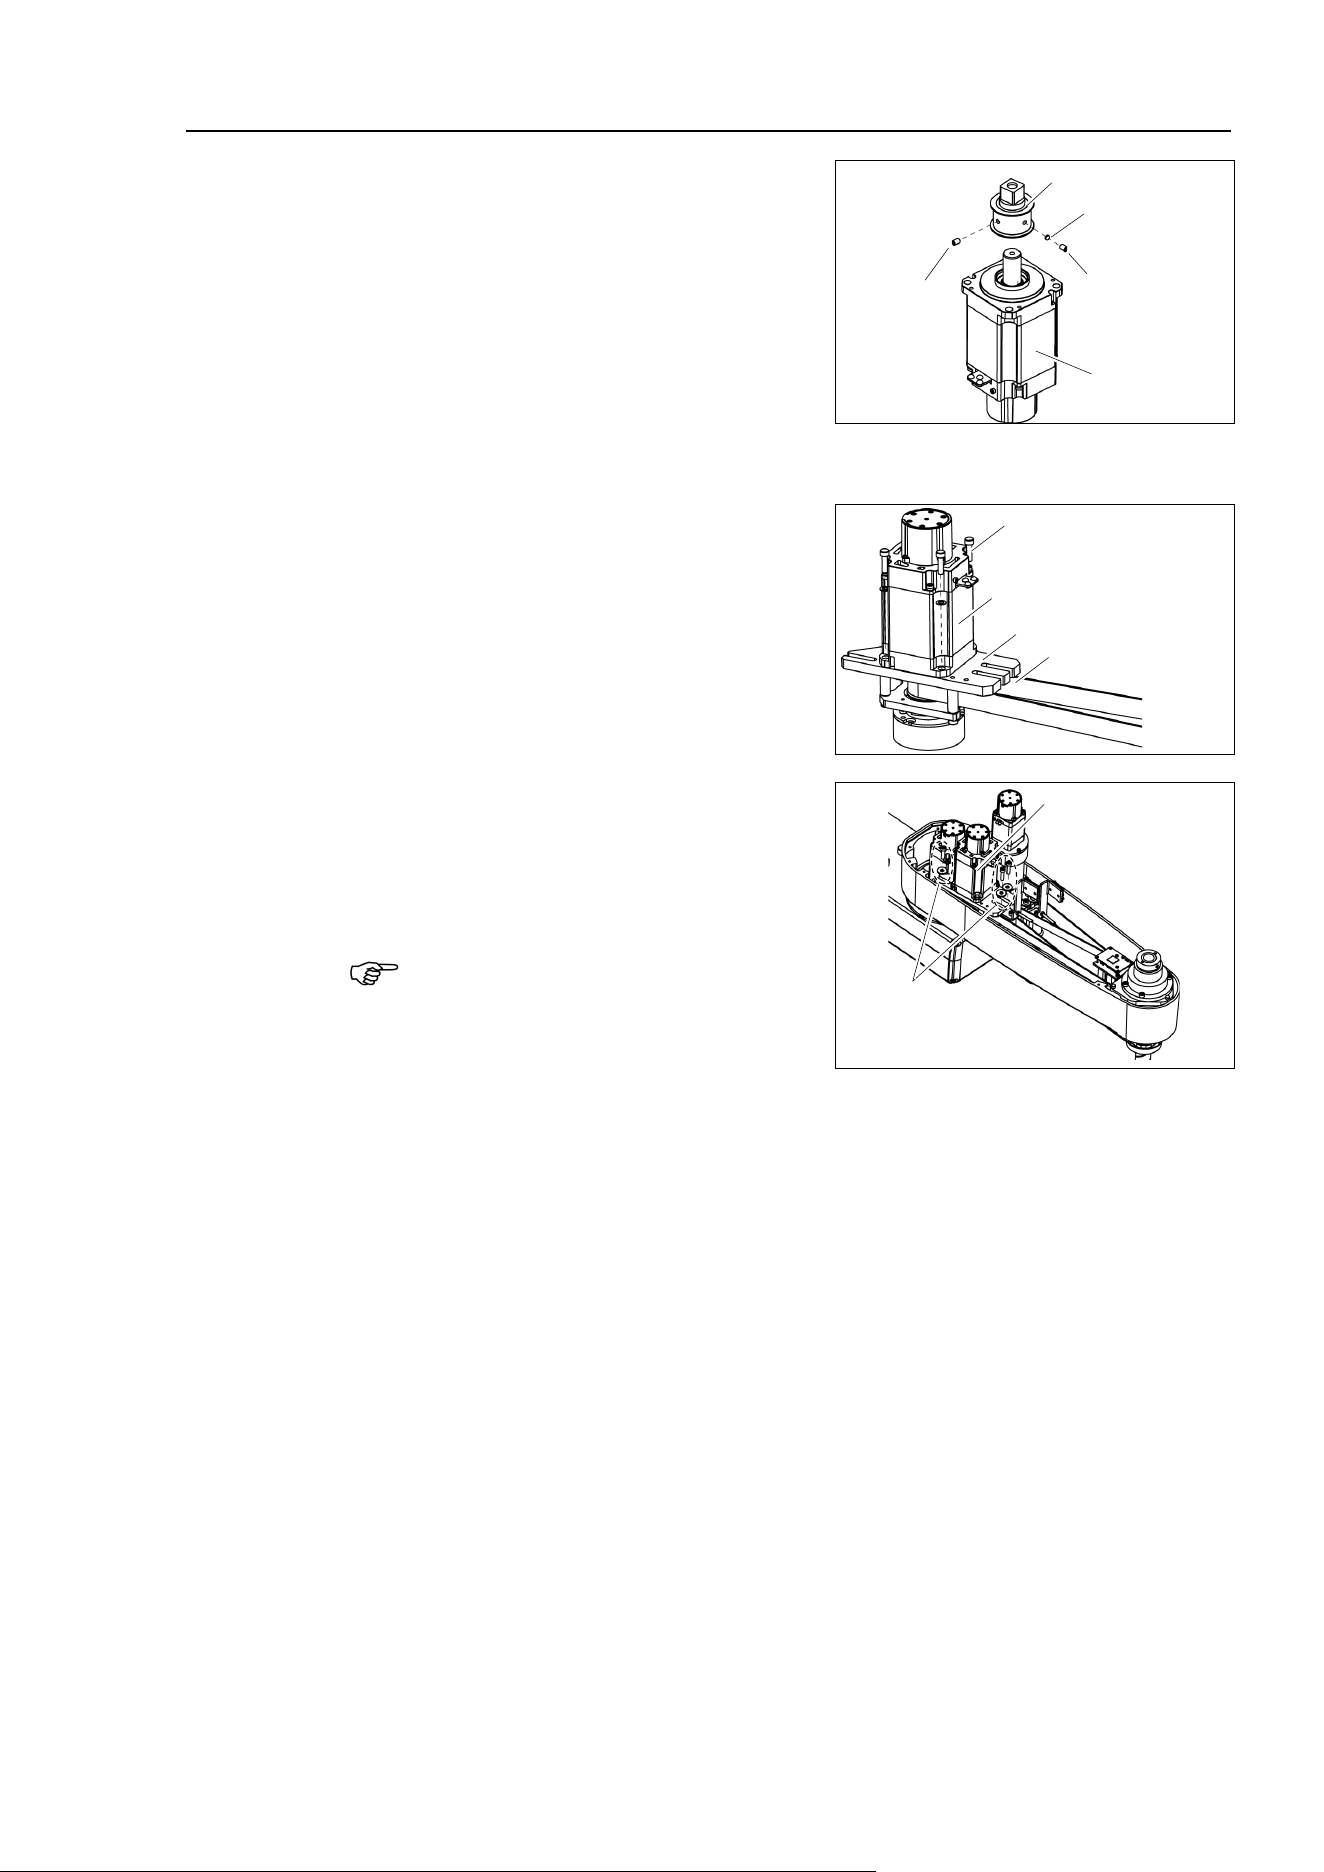
Maintenance 7. Joint #3
LS20-B Rev.4 111
Joint #3 motor
Installation
(1)
Mount
the pulley to the Joint #3 motor.
Secure the pulley where the pulley end
face
touches the motor shaft end face.
Joint #3
Motor
M4 Bushing
Pulley
M6×6
Set Screw
M6×6
Set Screw
Tighten one of the set
screws vertically on the flat face of the motor shaft.
Insert a bushing into the other set
screw hole to prevent damage to the motor shaft.
(2)
Mount the Joint #3 motor to the motor
plate while
aligning the hub to the brake
disc.
Before aligning the hub, set the motor so
that the
pulley will be inside of the Z belt.
Joint #3 Motor
Z Belt
4-M4×15+ Plain Washer
Motor Plate
(3)
Loosely
secure the Joint #3 motor unit to
the
Arm #2. Make sure that the teeth of
the timing belt are
engaged with those of
the pulley.
Check that the motor unit can be
moved
by hand,
and it will not tilt when pulled.
Joint #3 Motor Unit
3-M5×20
+ washer for slotted hole
If the unit is tilted, the belt will not have the proper
tension.
NOTE
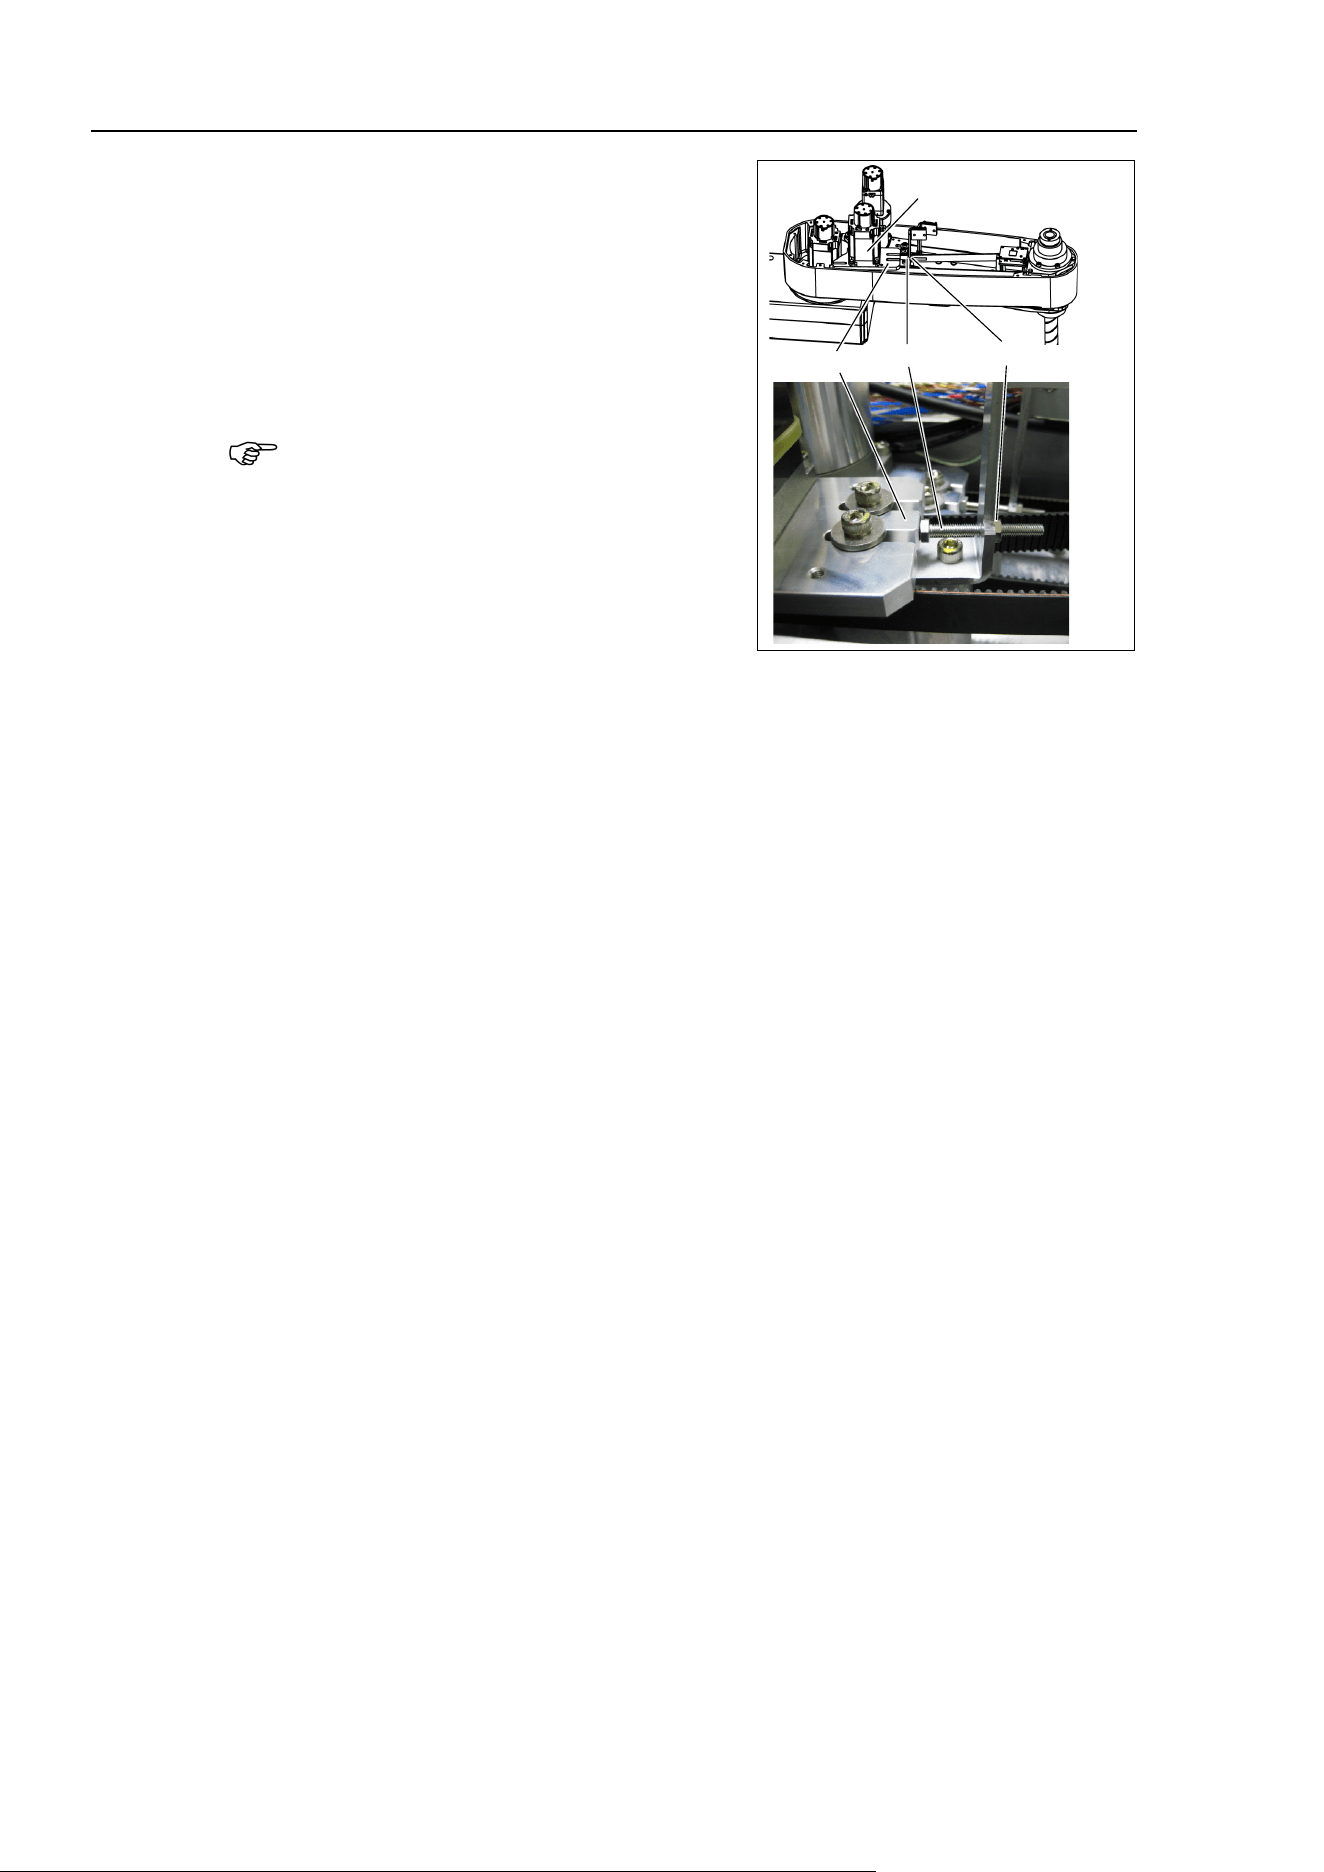
Maintenance 7. Joint #3
11
2 LS20-B Rev.4
(4)
Apply the proper tension to the Z belt, and
secure the Joint #3 motor unit.
Z belt tension
: 93N (9.5 ± 0.75 kgf)
Axial tension (if being pulled): 186N
To apply tension to the Joint #3 motor unit,
use the bolt at the front.
M4 Nut
Joint #3
Motor Unit
Plate
M4 Bolt
(4)-1 Loosen the nut and turn the bolt. Push in the Joint #3 motor unit slowly.
(4)-2 After fixing the Joint #3 motor unit, turn the bolt to leave from the plate.
(4)-3 Check the tension using the sonic tension meter.
For details, refer to Maintenance 7.4 Checking the Timing Belt Tension.
(4)-4 Repeat the steps (4)-1 through (4)-3 until you get appropriate tension.
(4)-5 After the adjustment, put the bolt back to its original position and fix it with
the nut.
(5)
Mount the User Plate and the Duct Plate.
For details, refer to Maintenance 3. Covers.
(6)
Connect the following connectors.
Connectors: X231, X43
(7)
Install the clip band removed in the removal step (5), bind the cables, and then fix them.
Do not allow unnecessary strain on the
cables.
(8)
Install the Arm Top Cover.
For details, refer to Maintenance: 3.1 Arm Top Cover.
(9)
Check if the Joint #3 moves in a Jog motion by operating from EPSON RC+ menu
-
[Tools]-[Robot Manager]-[Jog & Teach].
If the Manipulator oscillates with MOTOR ON and the following errors are detected,
Error 5041: Motor torque output failure in low power state.
Error 4241: Over speed during low power mode was detected.
or when the joint other than Joint #3
moves, the connector for other joint might be
connected to the Joint #3 motor. Check the connector connection.
(10)
Execute the calibration of Joints #3, #4.
For details, refer to Maintenance: 13. Calibration.
NOTE
Maintenance 7. Joint #3
LS20-B Rev.4 113
7.2 Replacing the Timing Belt
Name
Qty.
Note
Maintenance
part
Z belt 1 1618727
Tools
Hexagonal
wrench
width across flats: 2.5 mm
1
For M3 screw
width across flats: 3 mm
1
For M4 screw
width across flats: 4 mm
1
For M5 screw
Cross-point screwdriver (#2)
1
For M3, M4 screw
Torque wrench
1
Nippers
1
For cutting wire tie
Sonic tension meter 1
Z: Belt tension
93N (9.5 ± 0.75 kgf)
Material
Wire tie
-
For binding cables
A brake is mounted on the motor of Joints #3 and #4 to prevent the shaft from moving down
and rotating due to the weight of the end effector while the power to the Controller is OFF
or while the motor is in OFF status (MOTOR OFF).
Move the shaft down to its lower limit before the replacement procedure following the
removal steps.
NOTE
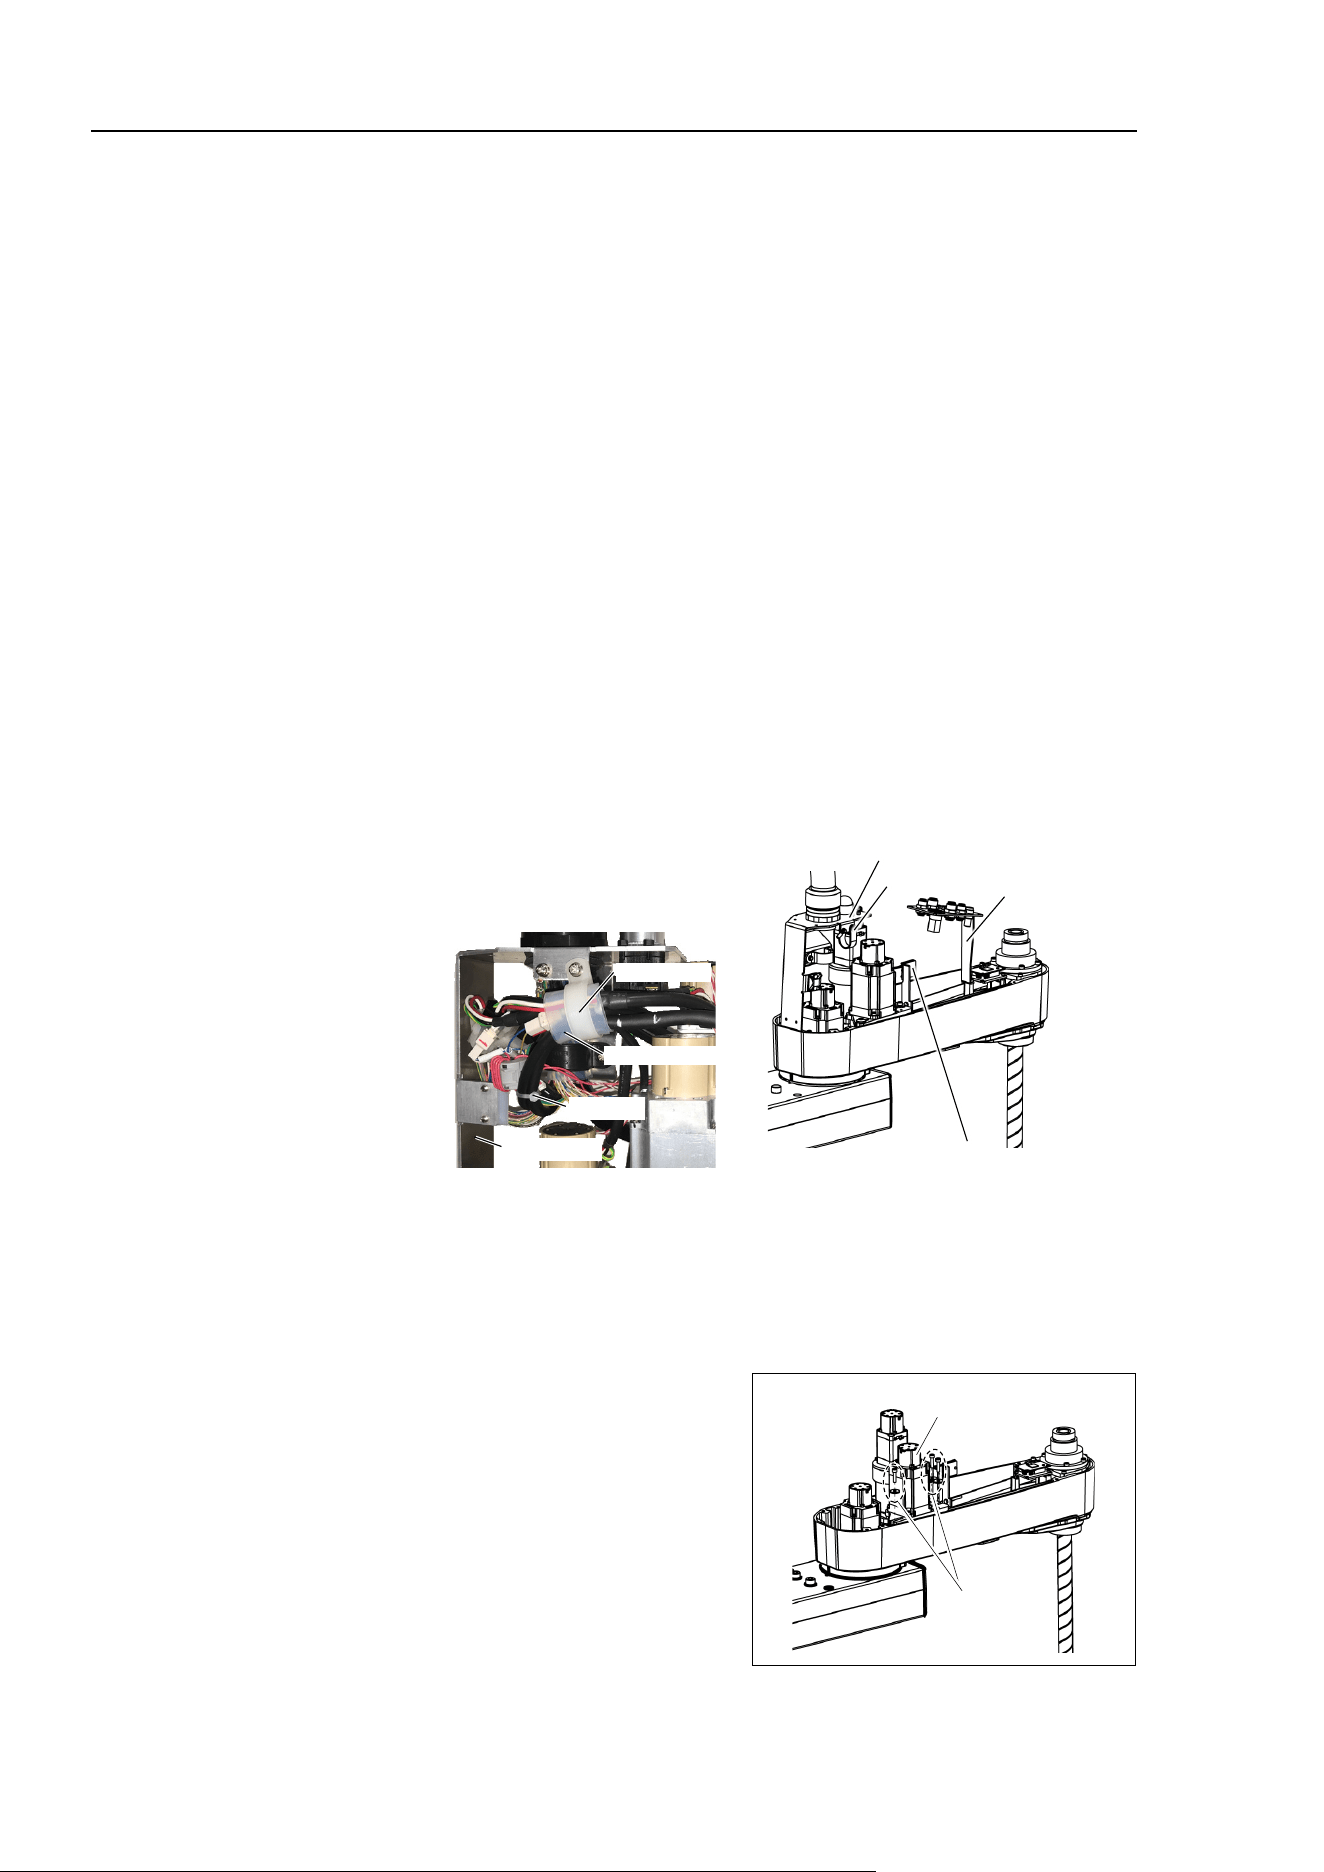
Maintenance 7. Joint #3
11
4 LS20-B Rev.4
Z belt
Removal
(1)
Turn ON the Controller.
(2)
Push down the shaft to its lower limit while pressing the brake release switch. Be sure
to keep enough space and prevent
the end effector hitting any peripheral equipment.
The brake release switch is applied to both Joints #3
and Joint #4.
When the brake release switch is pressed, the respective brakes of the Joint #3 and Joint
#4 are released simultaneously.
Be careful of the
shaft falling and rotating while the brake release switch is
being pressed
because
the shaft may be lowered by the weight of an end effector.
(3)
Turn OFF the Controller.
(4)
Remove the
Arm Top Cover.
For details, refer to Maintenance: 3.1 Arm Top Cover.
(5)
Remove the clip band and
sheet bundling the motor cables.
Cut off the wire tie fixing the
cables to the belt tensioner.
D
o not cut the wire tie (in the duct fittings outlet) that binds the cables to the duct
plate.
Removed parts
will be used again. Be careful not to lose them.
Clip Band
Wire Tie
Duct Plate
Silicon Sheet
Clip Band
Duct Plate
User Plate
Belt Tensioner
(6)
Disconnect the following connectors
.
Connectors: X231, X43 (Hold the clip to remove.)
(7)
Remove the User Plate
and Duct Plate.
For details, refer to Maintenance: 3. Covers.
(8)
Remove the screws for the Joint #3 motor
unit and pull out the
Joint #3 motor unit.
The washers for slotted holes will be used
again when installing the Z belt.
Be
careful
not to lose them.
Joint #3
Motor Unit
3-M5×20
+ washer fo
r
s
lotted hole
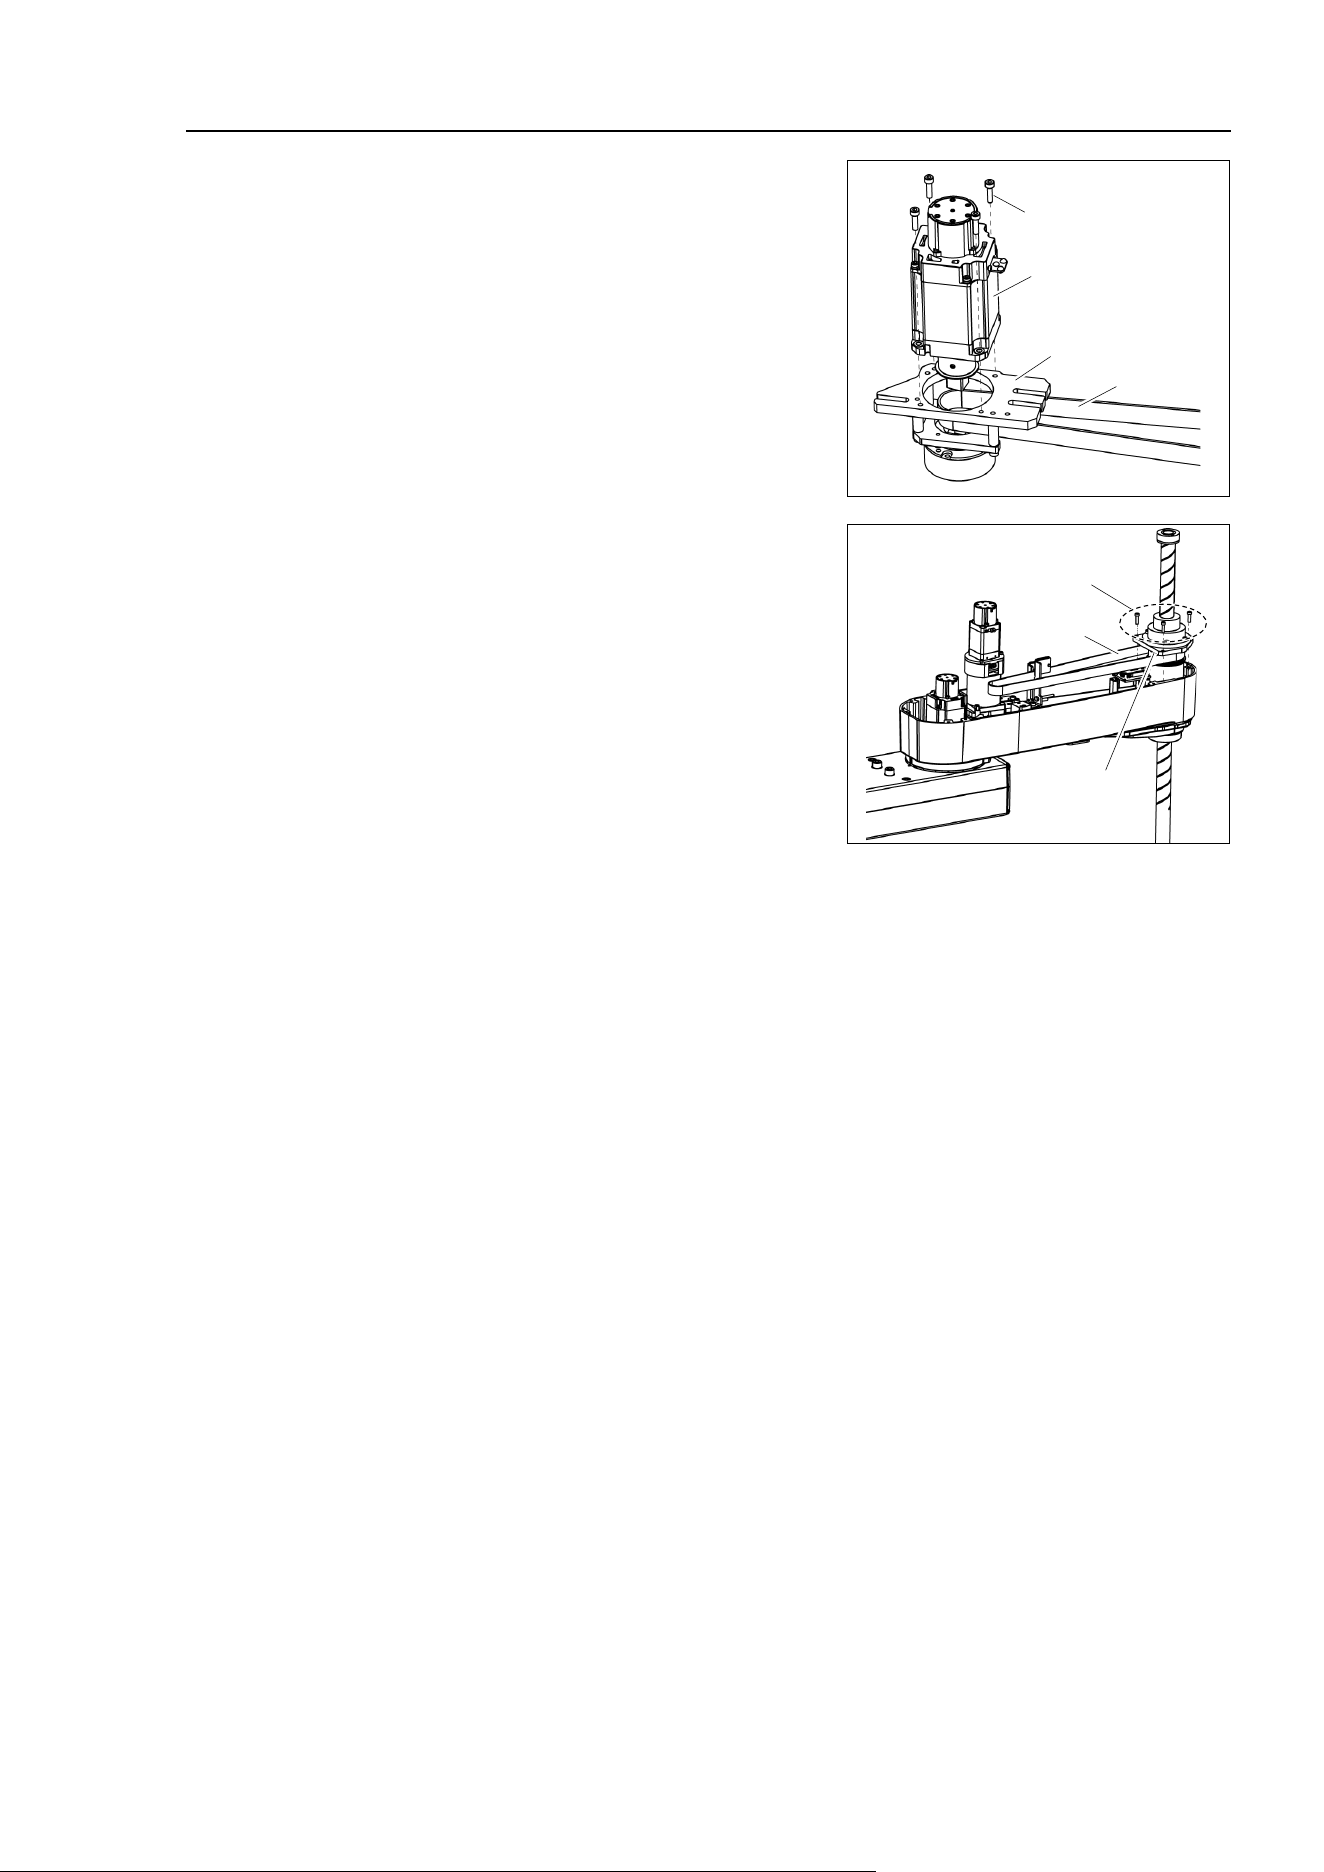
Maintenance 7. Joint #3
LS20-B Rev.4 115
(9)
Remove the Joint #3 motor from the motor
plate and pull out the Z belt.
The belt is placed around the pulley.
To
remove the Joint #3 motor, tilt the motor
slightly and pull it upward while avoiding
the
belt.
Motor Plate
Z Belt
Joint #3 Motor
4-M4×15+
Plain washer
(10)
Remove the screws for the spline plate.
Holding the spline plate
upward, pull out the
Z belt.
Z belt
Spline Plate
3-M4×15
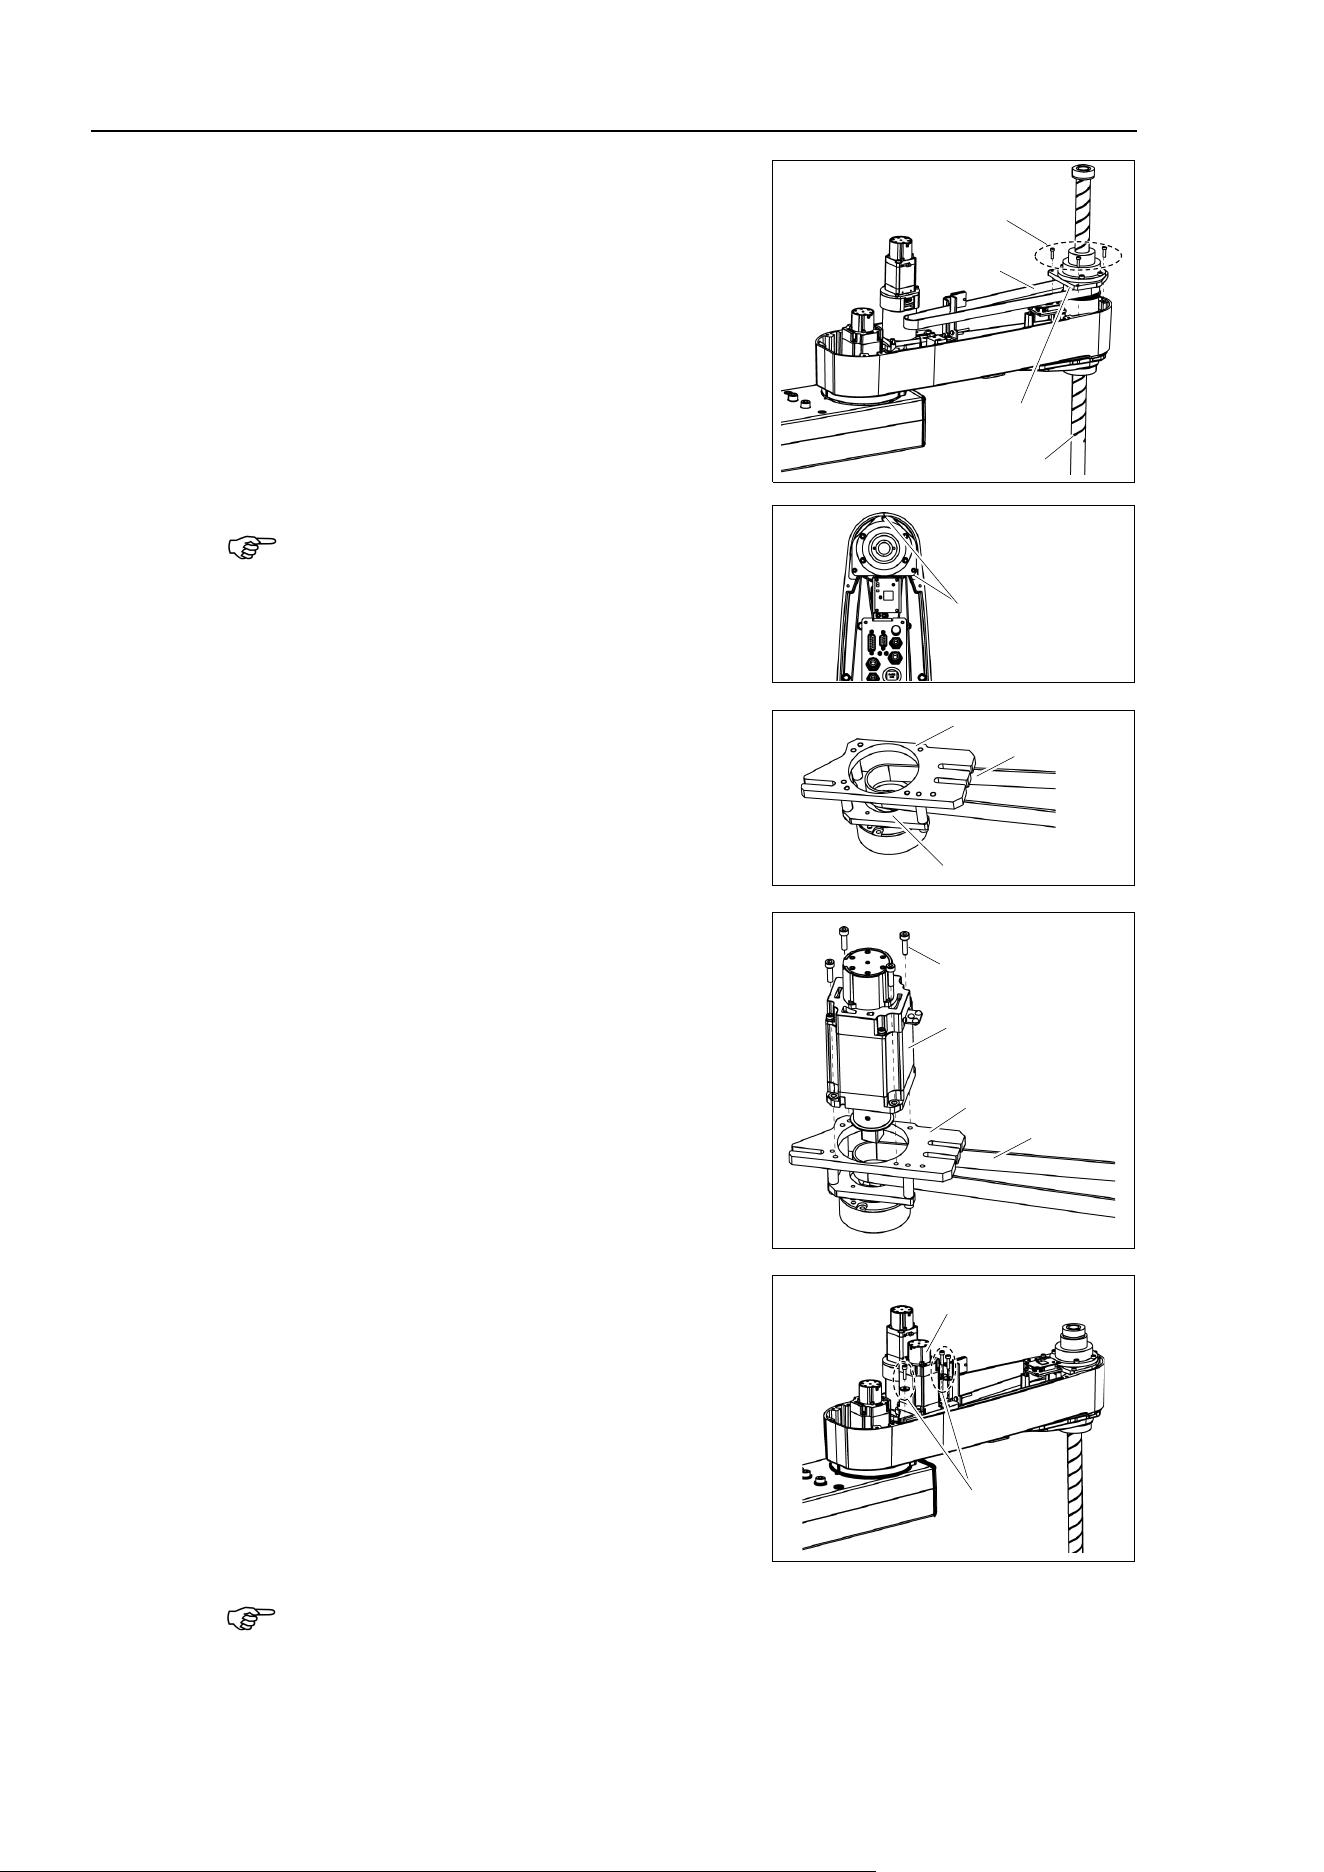
Maintenance 7. Joint #3
11
6 LS20-B Rev.4
Z belt
Installation
(1)
Pass
a new Z belt through the shaft.
Z Belt
Spline Plate
3-M4×15
Shaft
(2)
Lower the spline plate with the Z belt placed
around the spline plate pulley.
Secure the
spline plate with 3 screws.
Loosely tighten
screws temporarily so that the
spline plate can be moved by hand.
Tighten
the spline plate with the screws
while pushing
the front side of the Arm
#2 and the right side
face.
Faces to
push the
spline plate
(3)
P
ass the Z belt between the motor plate of the
Joint #3 motor unit and the brake
plate.
Brake Plate
Motor Plate
Z Belt
(4)
Mount the Joint #3 motor to the motor
plate
while aligning the hub to the
brake disc.
Install the motor so that the pulley will
be
inside of the Z belt.
Motor Plate
Z Belt
Joint #3 Motor
4-M4×15+
Plain washer
(5)
Loosely
secure the Joint #3 motor unit to the
Arm #2.
Make sure that the teeth of the timing
belt are
engaged with those of the
pulley.
Joint #3
Motor Unit
3-M5×20
+washer for
slotted hole
At this point, make sure that the Joint #3 motor unit can be moved by hand, and it
will not tilt when pulled.
If the unit is tilted, the belt will not have the proper
tension.
NOTE
NOTE
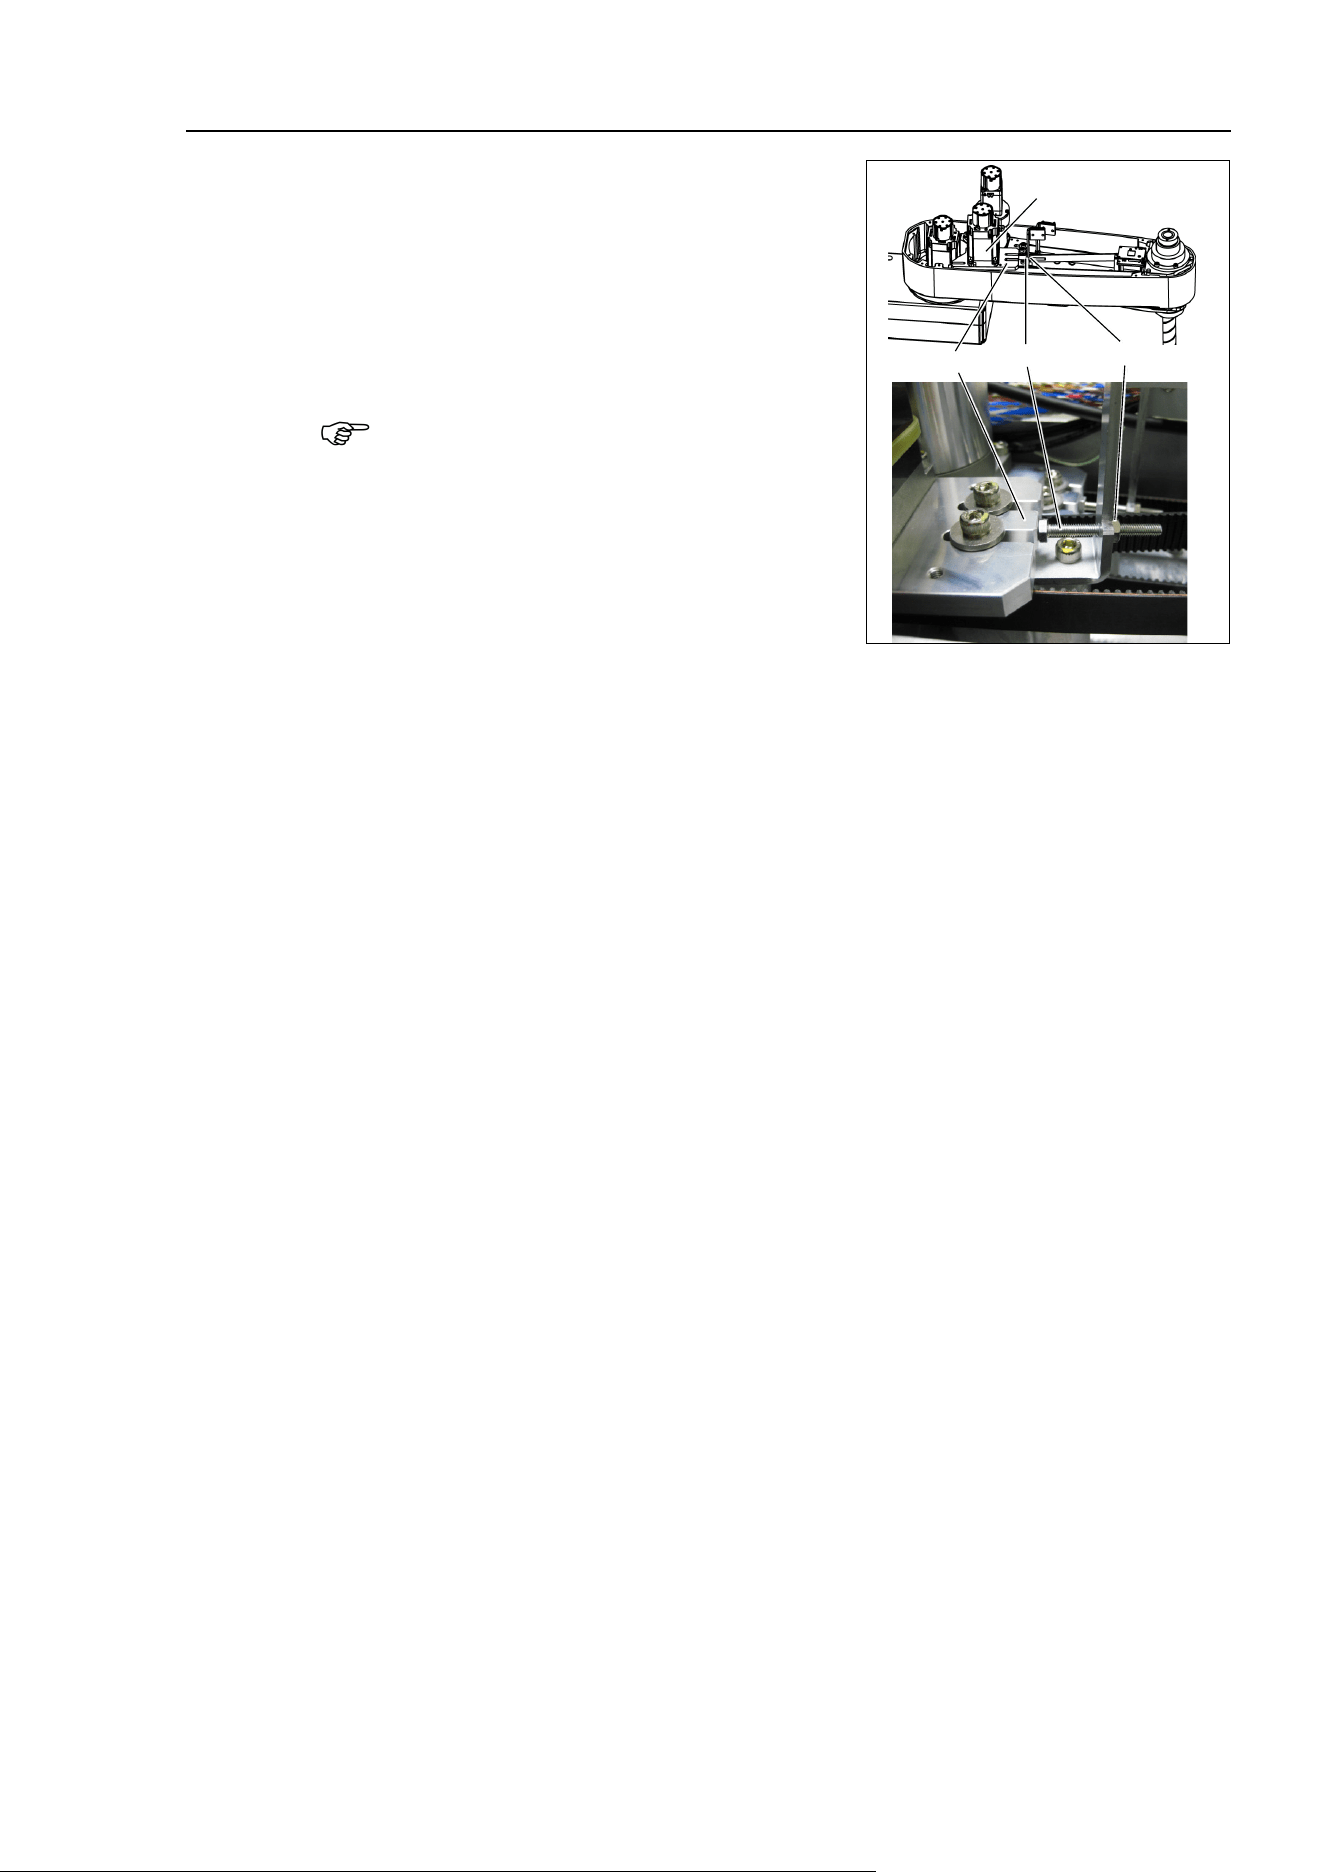
Maintenance 7. Joint #3
LS20-B Rev.4 117
(6)
Apply the proper tension to the Z belt, and
then secure the Joint #3 motor unit.
Z belt tension
: 93N (9.5 ± 0.75 kgf)
Axial tension (if being pulled): 186N
To apply tension to the Joint #3 motor unit,
use the bolt at the front of the plate.
M4 Nut
Joint #3
Motor Unit
Plate
M4 Bolt
(6)-1 Loosen the nut and turn the bolt. Push in the Joint #3 motor unit slowly.
(6)-2 After fixing the Joint #3 motor unit, turn the bolt to leave from the plate.
(6)-3 Check the tension using the sonic tension meter.
For details, refer to Maintenance 7.4 Checking the Timing Belt Tension.
(6)-4 Repeat the steps (6)-1 through (6)-3 until you get appropriate tension.
(6)-5 After the adjustment, put the bolt back to its original position and fix it with
the nut.
(7)
Connect the following connectors
.
Connectors: X231, X43
(8)
Mount
the User Plate and the Duct Plate.
For details, refer to Maintenance: 3. Covers.
(9)
Bind the cables with new wire ties at their original positions as before in the removal
step (5).
Bind the cables with the clip band. Do not allow unnecessary strain on
the
cables.
(10)
Install the
Arm Top Cover.
For details, refer to Maintenance: 3.1 Arm Top Cover.
(11)
Check if the Joint #
3 moves in a Jog motion by operating from EPSON RC+ menu
-
[Tools]
-[Robot Manager]-[Jog & Teach].
If the Manipulator oscillates with MotorON and the following errors are detected,
Error 5041: Motor torque output failure in low power state.
Error 4241: Over speed during low power mode was detected.
or when the joint other than Joint #
3
moves, the connector for the other joint might be
connected to the Joint #
3 motor. Check the connector connection.
(1
2)
Execute
the calibration of Joint #3.
For details, refer to Maintenance: 13. Calibration.
NOTE
Maintenance 7. Joint #3
11
8 LS20-B Rev.4
7.3 Replacing the Brake
Name
Qty.
Note
Maintenance
parts
Electromagnetic Brake 1 1499588
Tools
Hexagonal
wrench
width across flats: 1.5 mm
1
For M3 set screw
width across flats: 3 mm
1
For M4 screw
width across flats: 4 mm
1
For M5 screw
Torque wrench
1
Nippers
1
For cutting wire tie
Sonic tension meter 1
Z: Belt tension
93N (9.5 ± 0.75 kgf)
Material
Wire tie
-
For binding cables
A brake is mounted on the motor of Joints #3 and #4 to prevent the shaft from moving down
and rotating due to the weight of the end effector while the power to the Controller is OFF
or while the motor is in OFF status (MOTOR OFF).
Move the shaft down to its lower limit before the replacement procedure following the
removal steps.
NOTE
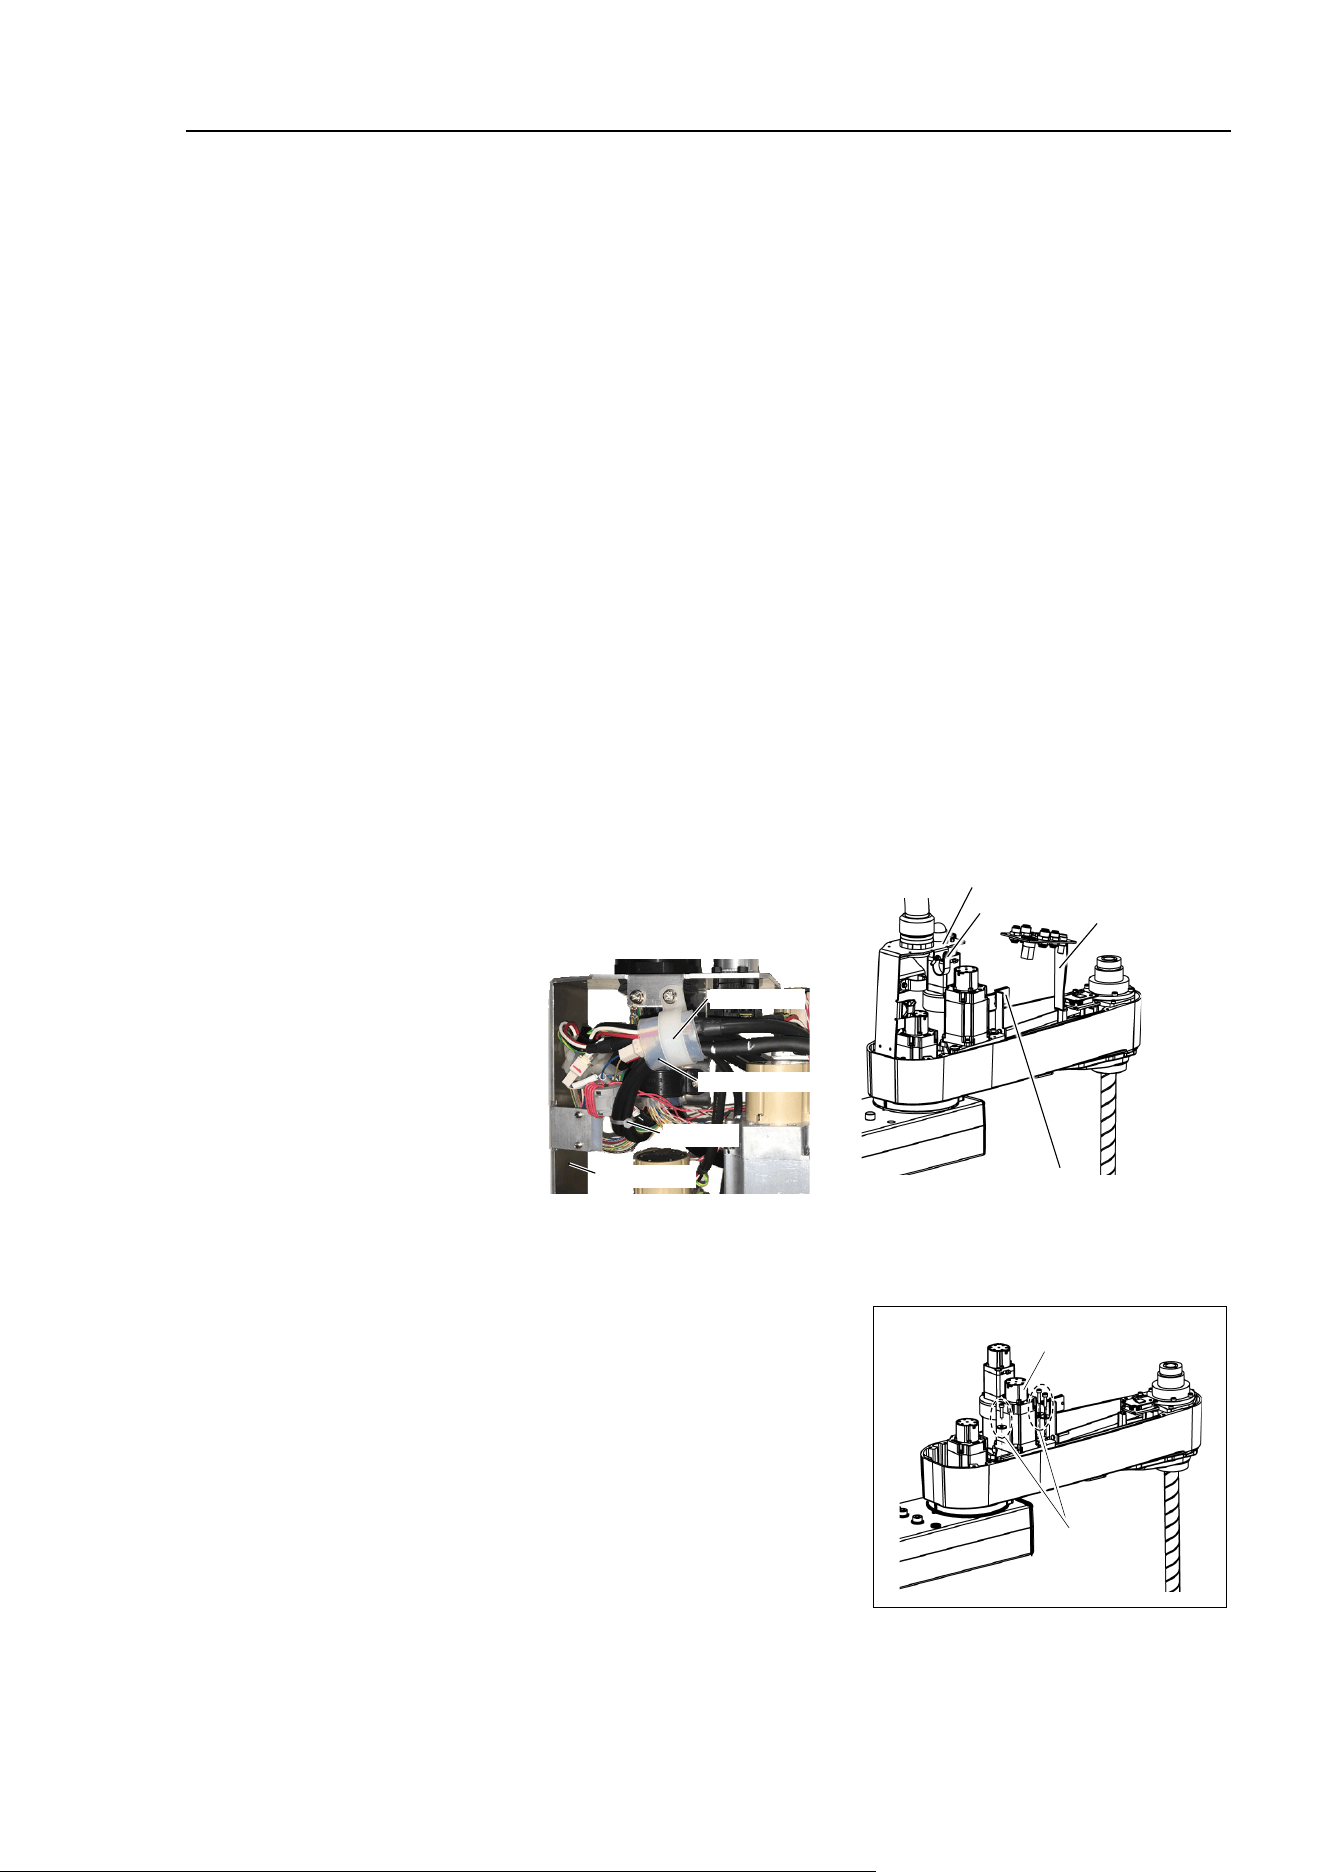
Maintenance 7. Joint #3
LS20-B Rev.4 119
Joint #3 brake
Removal
(1)
Turn ON the Controller.
(2)
Push down the shaft to its lower limit while pres
sing the brake release switch.
Be sure to keep enough space and prevent
the end effector hitting any
peripheral
equipment.
The brake release switch is applied to both Joints #3 and Joint #4.
When the brake release switch is pressed, the respective brakes of the Joint #3 and Joint
#4 are
released simultaneously.
Be careful of the
shaft falling and rotating while the brake release switch is
being
pressed
because the shaft may be lowered by the weight of an end effector.
(3)
Turn OFF the Controller.
(4)
Remove the
Arm Top Cover.
For details, refer to Maintenance: 3.1 Arm Top Cover.
(5)
Remove the clip band and
sheet bundling the motor cables.
Cut off the wire tie fixing the cable
s to the belt tensioner.
D
o not cut the wire tie (in the duct fittings outlet) that binds the cables to the duct
plate.
Removed parts
will be used again. Be careful not to lose them.
Clip Band
Wire Tie
Duct Plate
Silicon Sheet
Clip Band
Duct Plate
User Plate
Belt Tensioner
(6)
Disconnect the following connectors.
Connectors: X231, X43, BR3
(7)
Remove the bolts
fixing the Joint #3 motor
unit.
The washers for slotted holes will be used
again when installing the Z belt.
Be careful
not to lose them.
Joint #3
Motor Unit
3-M5×20
+ washer for
slotted hole
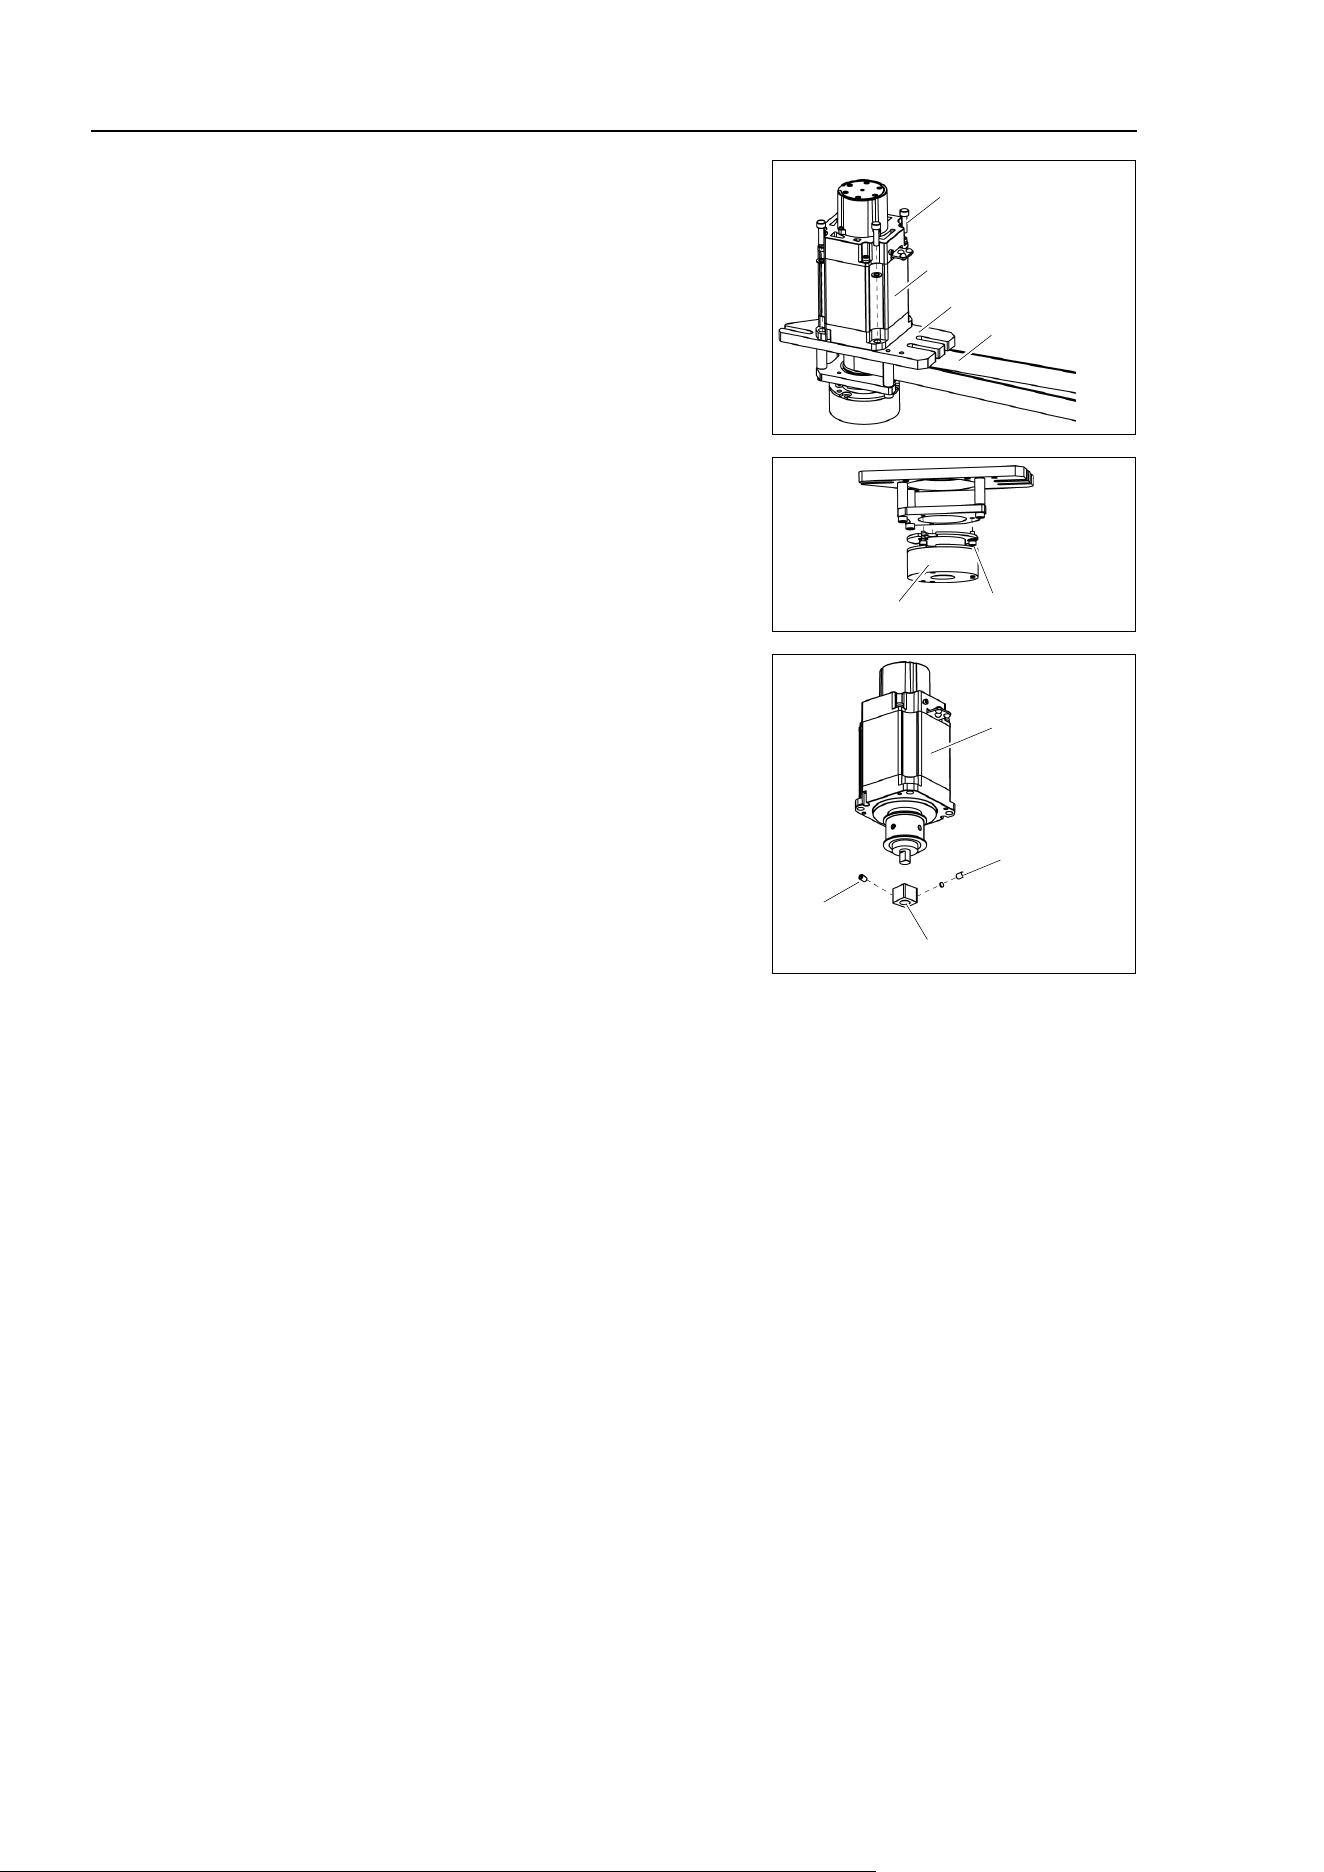
Maintenance 7. Joint #3
120 L
S20-B Rev.4
(8)
Remove the Joint #3 motor from the motor
plate.
The
Z belt is placed around the pulley.
To
remove the Joint #3 motor, tilt the motor
slightly and pull it upward while avoiding the
belt.
Joint #3 Motor
4-M4×15+
Plain washer
Motor Plate
Z Belt
(9)
Remove the brake from the brake plate.
Brake
3-M3×8
(10)
Loosen the screws of the brake hub and
remove
the brake hub from the pulley shaft
of the Joint
#3 motor unit.
There is a brass bushing on one of the set
screws.
Be careful not to lose it.
Joint #3
Motor
M3×4 Set Screw
+M3 Bushing
Brake Hub
M3×4
Set Screw
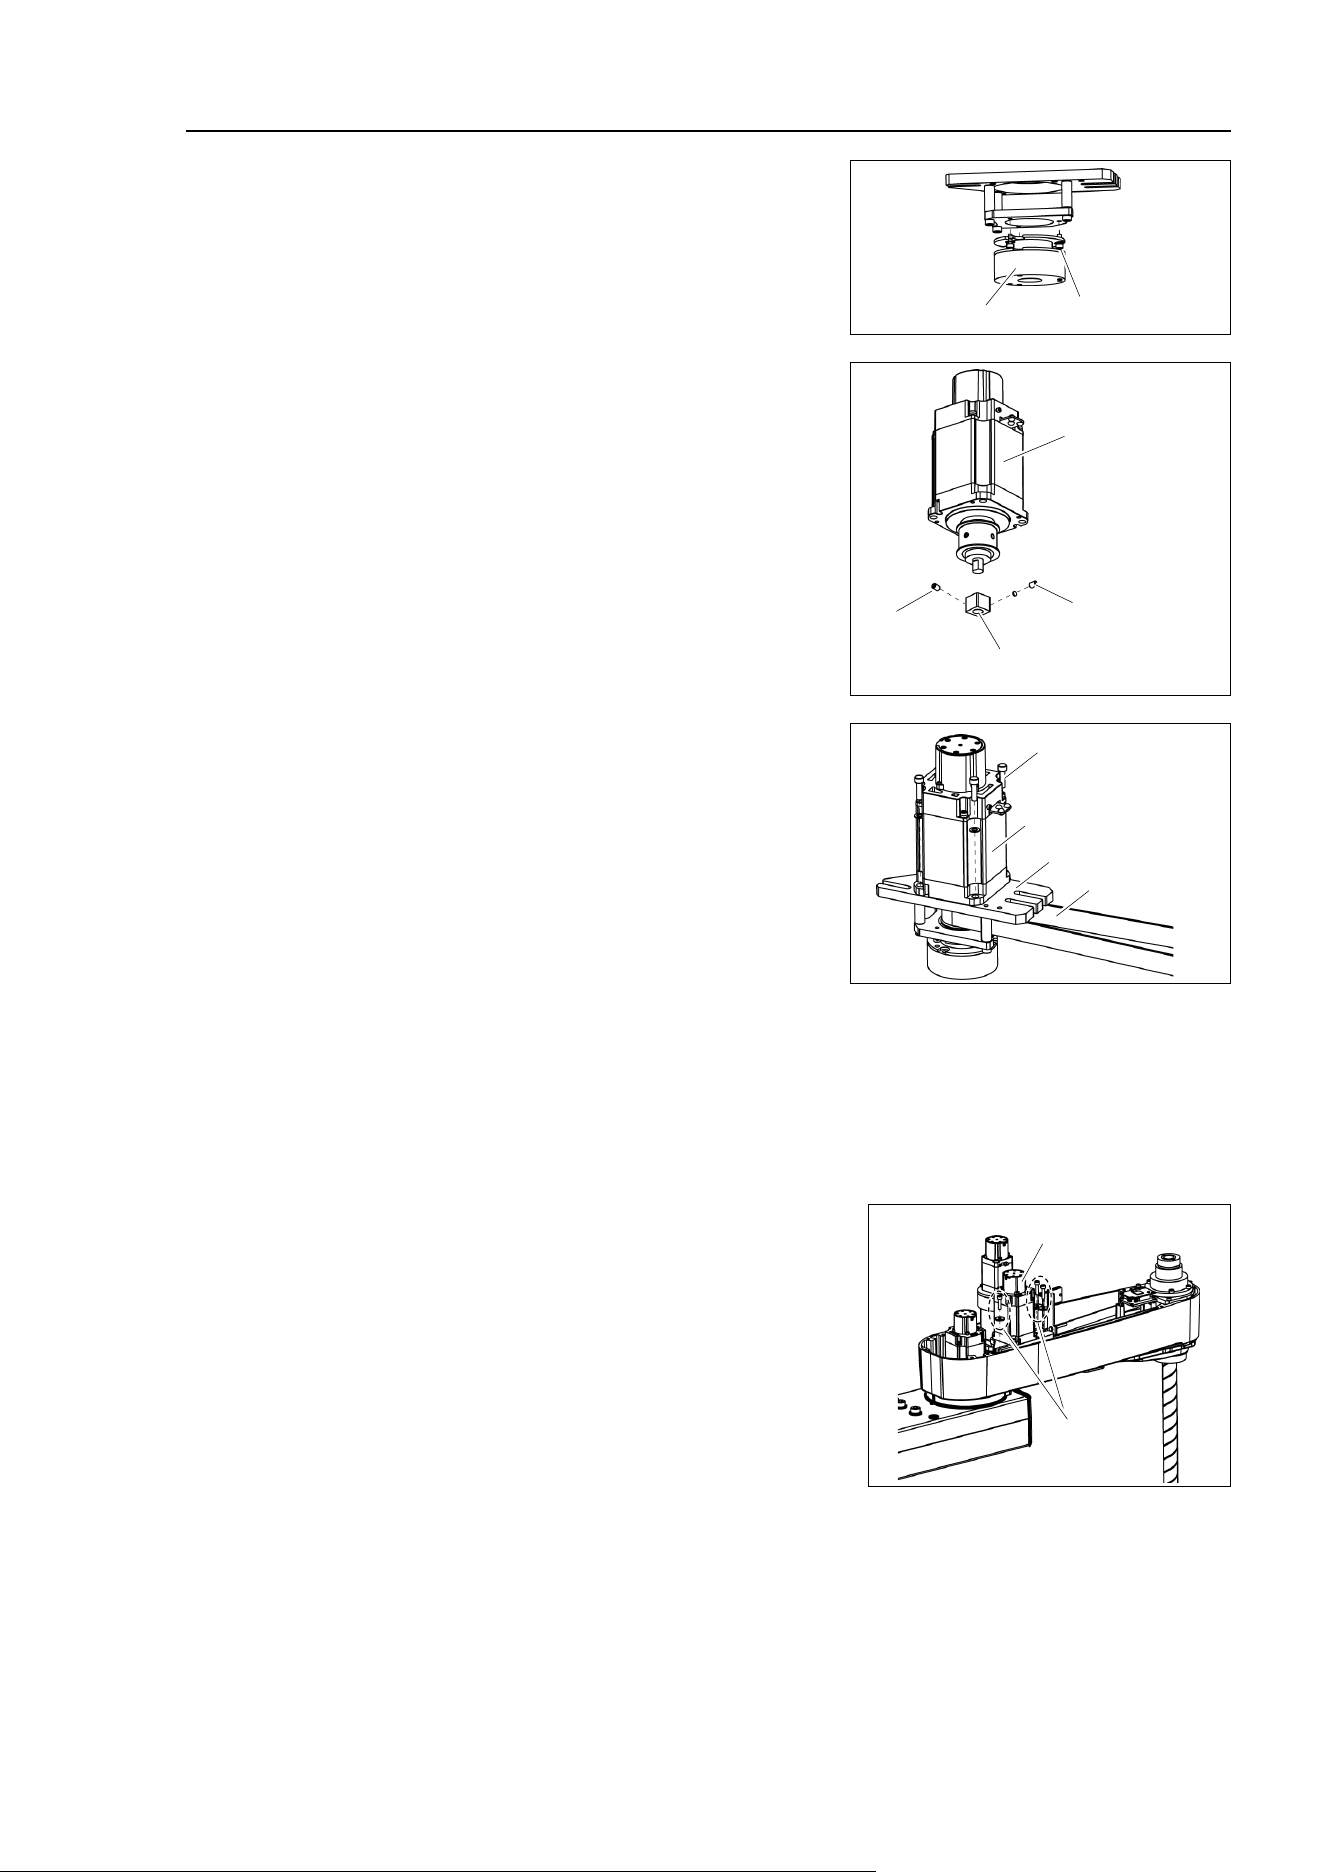
Maintenance 7. Joint #3
LS20-B Rev.4 121
Joint #3 brake
Installation
(1)
Mount the brake to the brake plate.
Brake
3-M3×8
(2)
Mount the brake hub to the
pulley of the
Joint #3 motor.
Fix the brake hub while aligning it to the
end
face of the pulley.
Tighten one of the set screws
vertically on
the flat face of the motor shaft.
Insert a bushing into the other set screw
hole
to prevent damage to the motor shaft.
Joint #3
Motor
M3×4 Set Screw
+M3 Bushing
Brake hub
M3×4
Set Screw
(3)
Mount the Joint #3 motor to the motor
plate
while aligning the hub to the
brake disc.
Before aligning the hub, set the motor so
that
the pulley will be inside of the Z belt.
Joint #3 Motor
4-M4×15+
Plain washer
Motor Plate
Z Belt
When the brake disc is not aligned, manually adjust the position by following the
steps
below.
1. Connect the connector BR3.
2. Press the brake release switch to release the brake.
3. Adjust the brake disc manually so that the hole is at the center.
(4)
Apply the proper tension to the Z belt, and
secure the Joint #3 motor unit.
For details, refer to the installation steps in
Maintenance 7.2 Replacing the Timing Belt.
Joint #3
Motor Unit
3-M5×20
+washer for
slotted hole
(5)
Mount the User Plate and the Duct Plate.
For details, refer to Maintenance 3. Covers.
(6)
Connect the following
connectors.
Connectors: X231, X43, BR3
Maintenance 7. Joint #3
122 L
S20-B Rev.4
(7)
Mount
the Arm Top Cover.
For details, refer to Maintenance: 3.1 Arm Top Cover.
(8)
Check if the Joint #
3 moves in a Jog motion by operating from EPSON RC+ menu
-
[Tools]
-[Robot Manager]-[Jog & Teach].
If the Manipulator oscillates with
MOTOR ON and the following errors are detected,
Error 5041: Motor torque output failure in low power state.
Error 4241: Over speed during low power mode was detected.
or when the joint other than Joint #
3 moves, the connector for other joint might be
connected to the Joint #
3 motor. Check the connector connection.
(9)
Execute the calibration of Joint #3.
F
or details, refer to Maintenance: 13. Calibration.
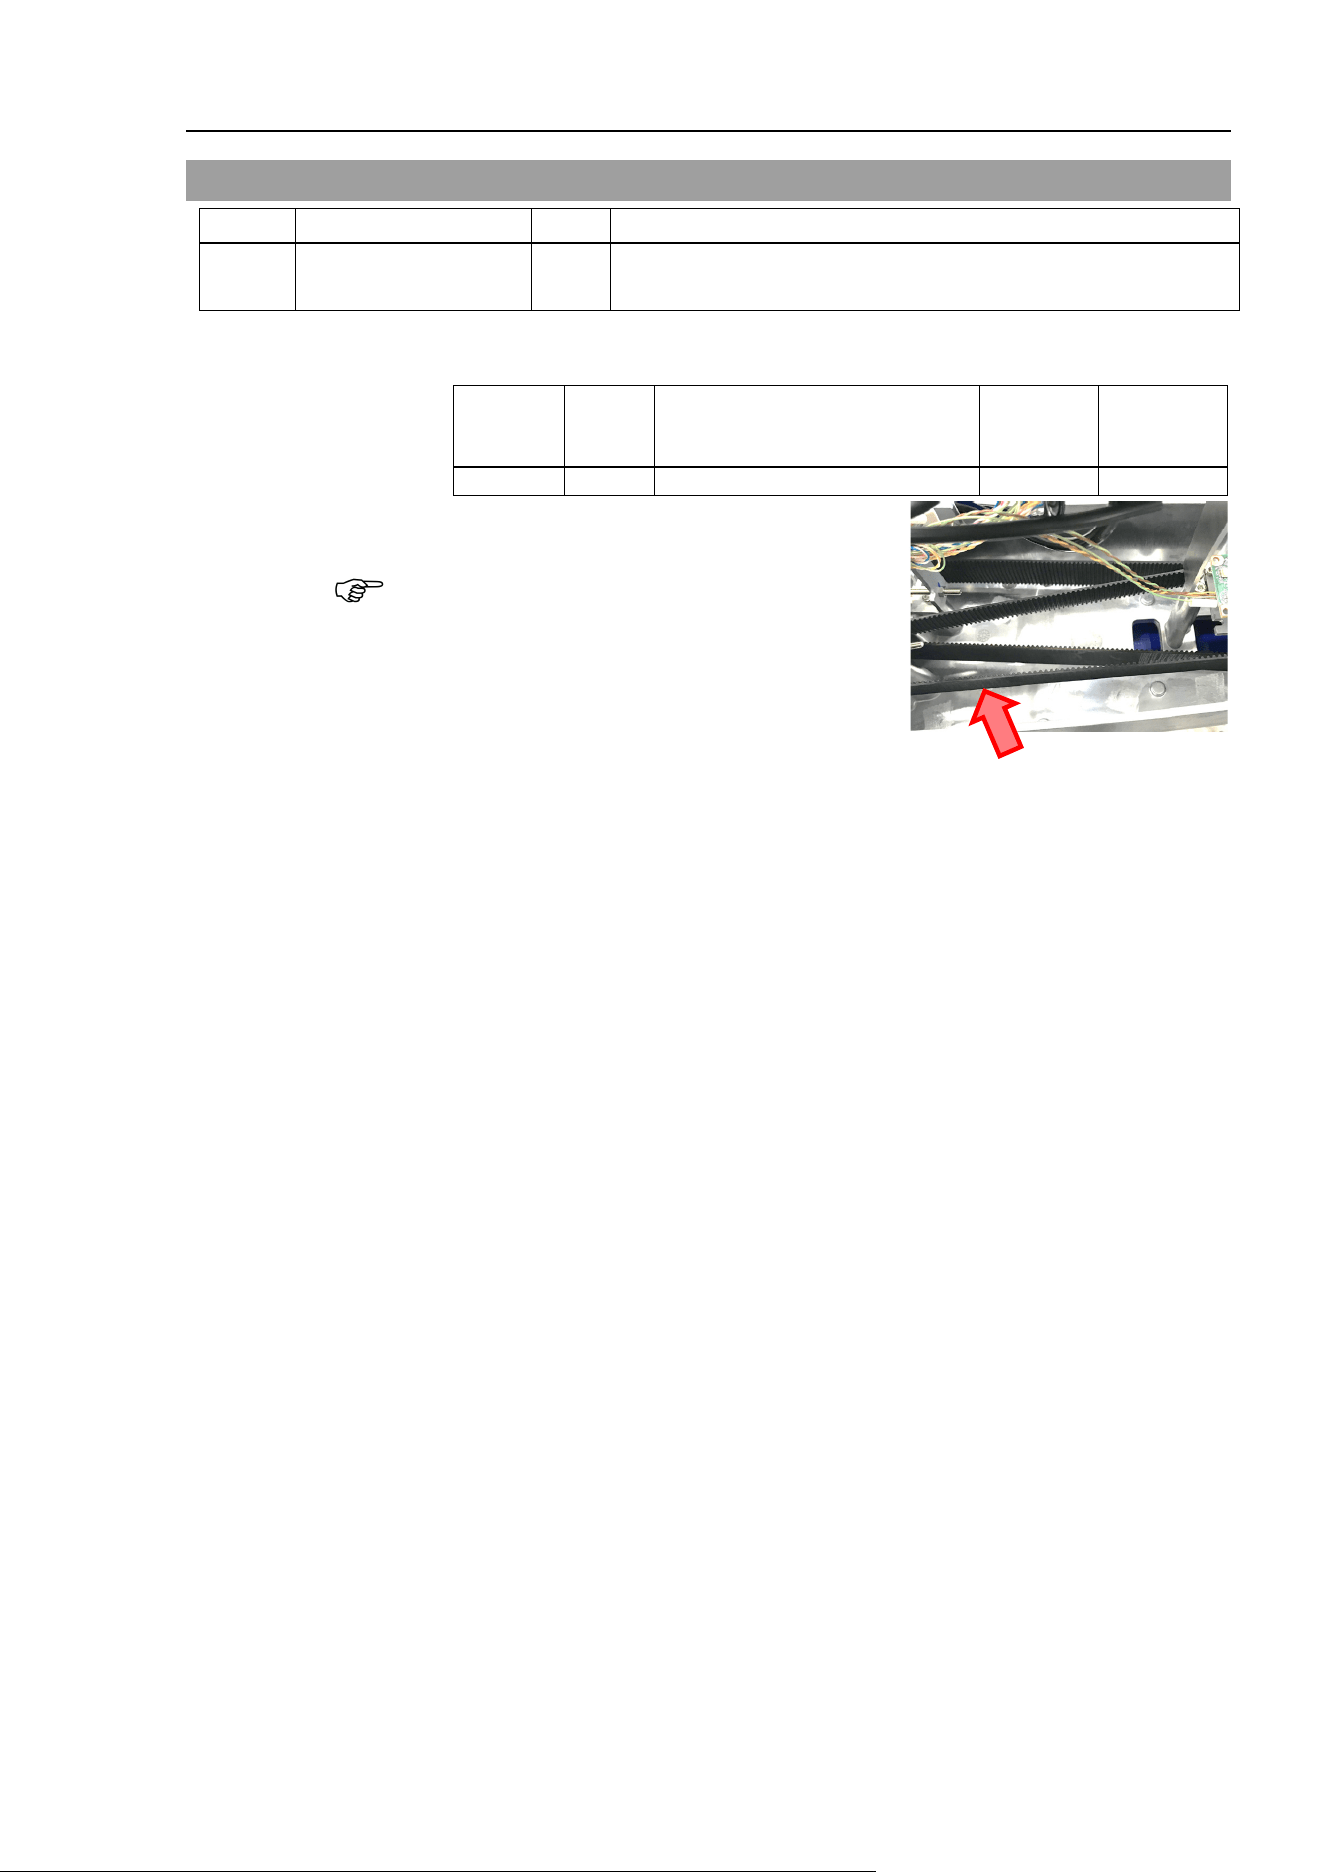
Maintenance 7. Joint #3
LS20-B Rev.4 123
7.4 Checking the Timing Belt Tension (Z Belt)
Name
Qty.
Note
Tool Sonic tension meter 1
Fo
r details of usage and measurement methods of the tension
meter, refer to the instruction manual of the tension meter.
Joint #3
Belt tension
check
(1)
Enter appropriate setting values to the sonic tension meter.
Model Belt
Unit mass M
[g/ (1 mm width ×1 m
length)]
Width W
[mm]
Span S
[mm]
LS20-B
Z belt
2.5
17
367
(2)
Strum
the belt and measure tension.
Measurement failure may occur if the microphone
touches the belt during measurement.
NOTE
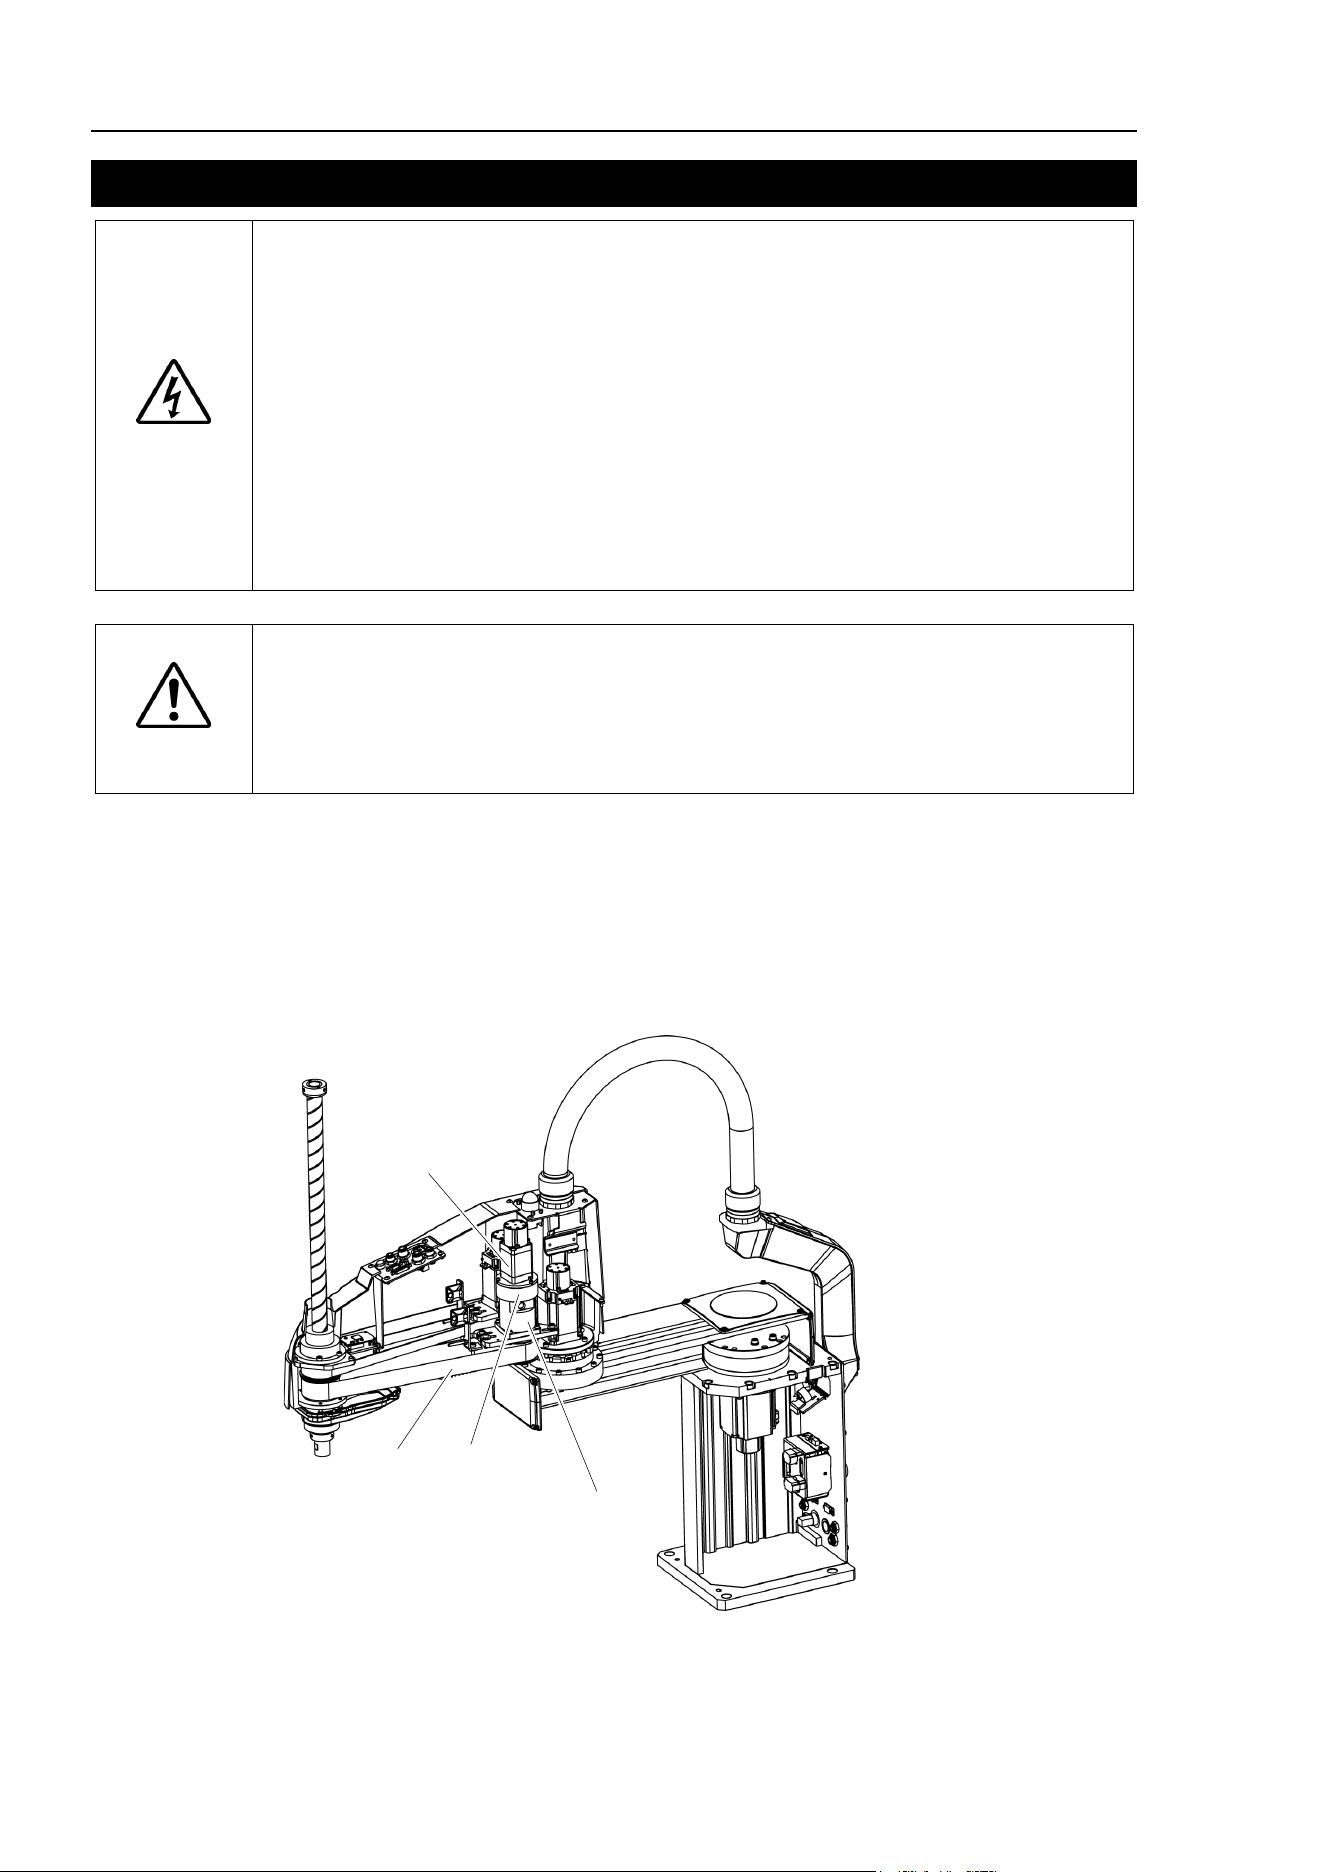
Maintenance 8. Joint #4
124 L
S20-B Rev.4
8. Joint #4
WARNING
■
Do not insert or pull out the motor connectors while the power to the robot system
is turned ON. Inserting or pulling out the motor connectors
with the power ON is
extremely hazardous and may result
in serious bodily injury as the Manipulator
may move abn
ormally, and also may result in electric shock and/or malfunction of
the robot system.
■
To shut off power to the robot system, pull out the power plug from the power
source. Be sure to connect the AC power cable to a power receptacle. DO
NOT connect it directly to a factory power source.
■
Before performing any replacement, turn OFF the Controller and related
equipment,
and then pull out the power plug from the power source.
Performing any replacement with the power ON is extremely hazardous and may
result in
electric shock and/or malfunction of the robot system.
C
AUTION
■
Be careful not to apply excessive shock to the motor shaft when replacing
the
motor
s. The shock may shorten the life cycle of the motors and encoder and/or
damage them.
■
Never disassemble the motor and encoder. A disassembled motor and encoder
will cause a positional gap and cannot be used
again.
After parts have been replaced (motors, reduction gear units, brakes, timing belts, ball screw
spline unit, etc.), the Manipulator cannot operate properly because a mismatch exists
between the origin stored in each motor and its corresponding origin stored in the Controller.
After replacing the parts, it is necessary to match these origins.
The process of aligning the two origins is called “Calibration”.
Refer to Maintenance: 13. Calibration to execute the calibration.
Joint #4 Motor
Joint #4
Brake
Joint #4
Reduction Gear Unit
U Belt
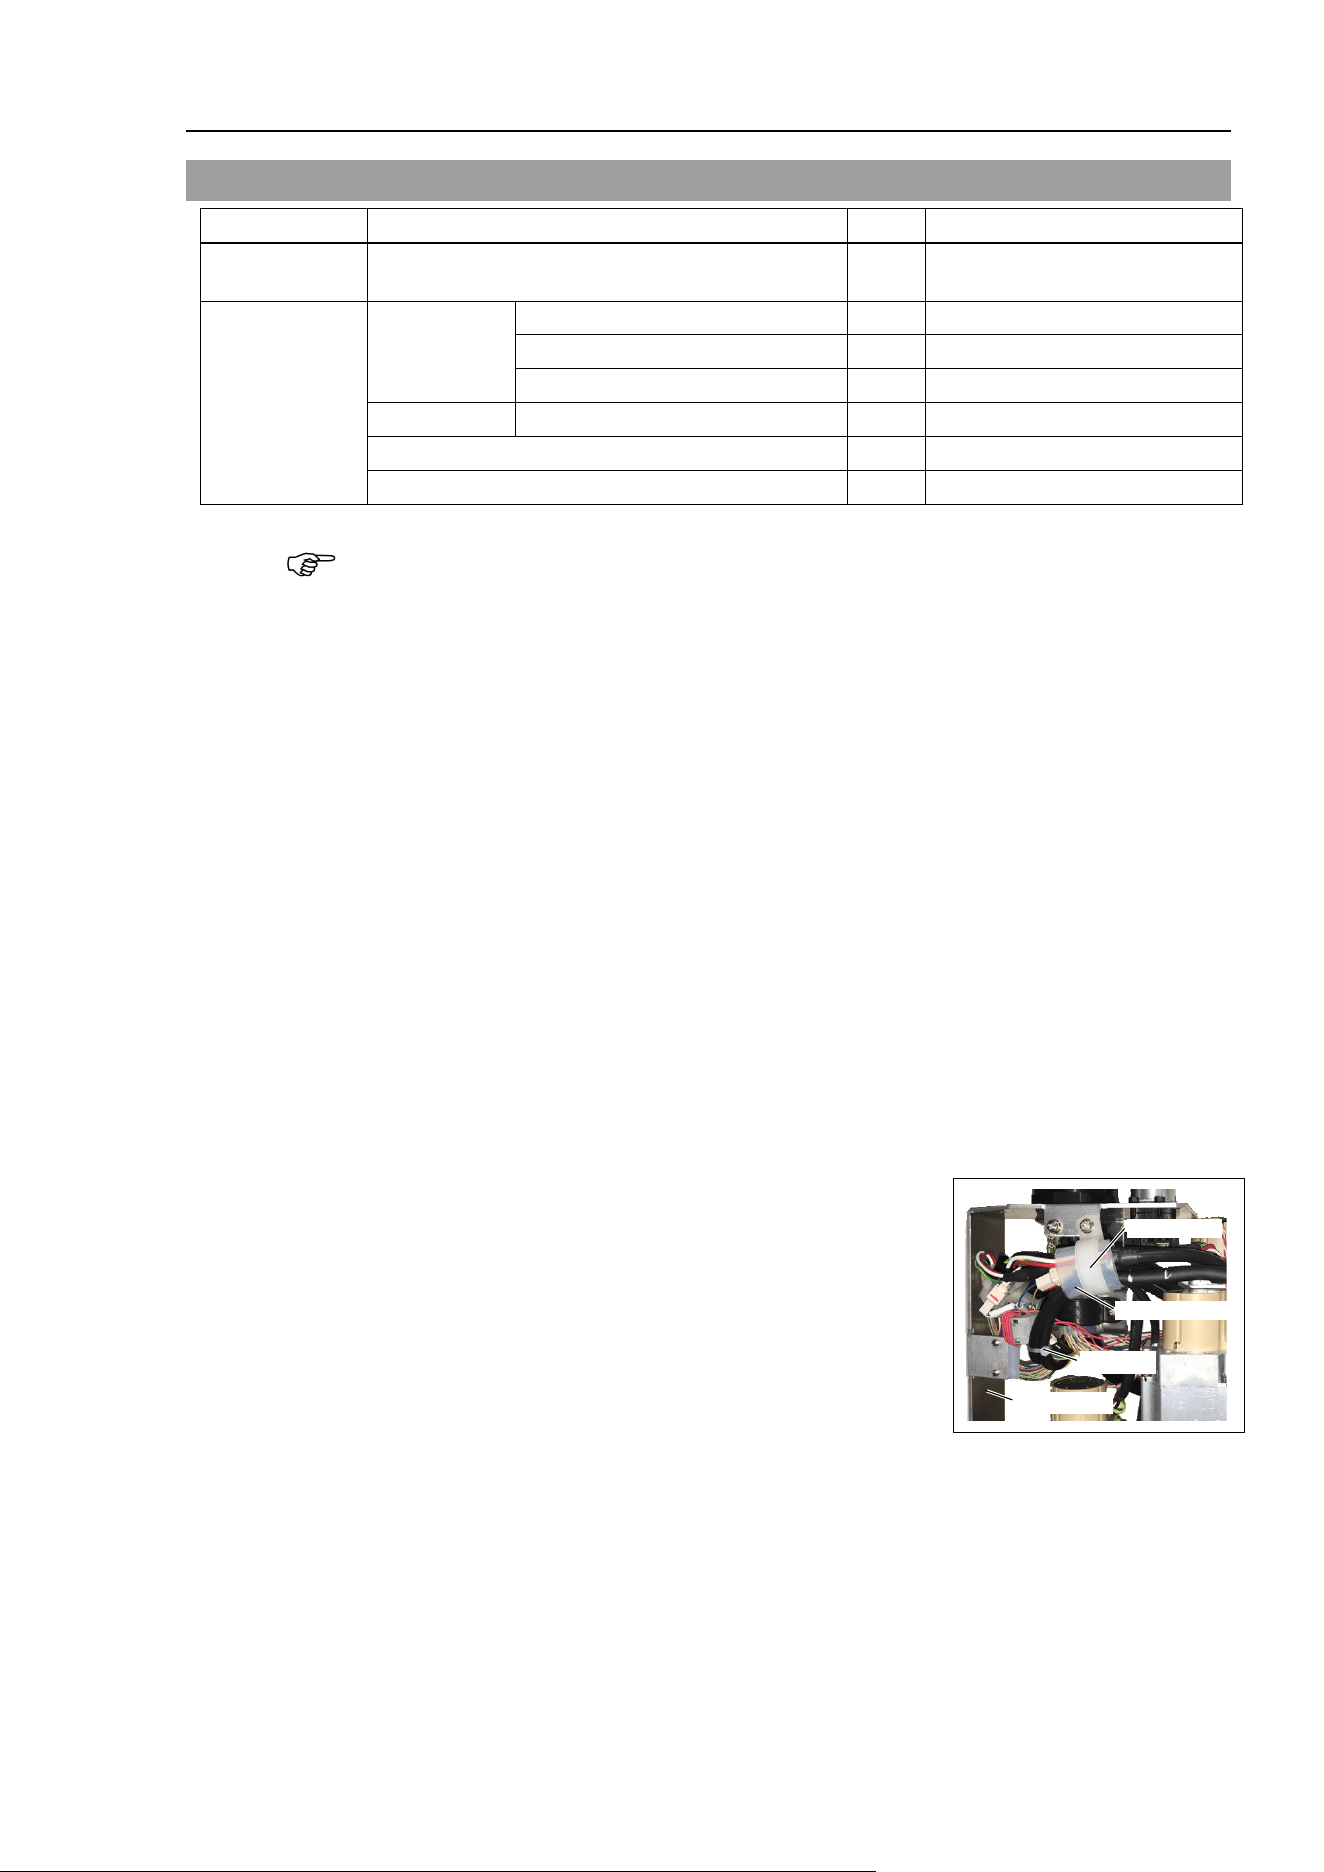
Maintenance 8. Joint #4
LS20-B Rev.4 125
8.1 Replacing Joint #4 Motor
Name
Qty.
Note
Maintenance
part
AC Servo Motor 150 W 1 1646520
Tools
Hexagonal
wrench
width across flats: 1.5 mm
1
For M3 Set screw
width across flats: 3 mm
1
For M4 screw
width across flats: 4 mm
For M5 screw
Spanner
width across flats: 7 mm
1
For M4 bolt, M4 nut
Cross-point screwdriver (#2)
1
For M4 screw
Torque wrench
1
A brake is mounted on the motor of Joints #3 and #4 to prevent the shaft from moving down
and rotating due to the weight of the end effector while the power to the Controller is OFF
or while the motor is in OFF status (MOTOR OFF).
Move the shaft down to its lower limit before the replacement procedure following the
removal steps.
Joint #4 motor
Removal
(1)
Turn ON the Controller.
(2)
Push down the shaft to its lower limit while pres
sing the brake release switch.
Be sure to keep enough space and prevent
the end effector hitting any
peripheral
equipment.
The brake release switch is applied to both Joints #3 and Joint #4.
When the brake release switch is pressed, the respective brakes of the Joint #3 and Joint
#4 are released simultaneously.
Be careful of t
he shaft falling and rotating while the brake release switch is
being pressed
because
the shaft may be lowered by the weight of an end effector.
(3)
Turn OFF the Controller.
(4)
Remove the
Arm Top Cover.
For details, refer to Maintenance: 3.1 Arm Top Cover.
(5)
Remove the
clip band and sheet binding the motor
cables.
Removed parts
will be used again. Be careful not to
lose
them.
At this point, do not cut the wire tie (in the duct
fittings
outlet) that binds the cables to the duct
plate.
Clip Band
Wire Tie
Duct Plate
Silicon Sheet
(6)
Remove
the User Plate and Duct Plate.
For details, refer to Maintenance 3. Covers.
(
7)
Disconnect
the following connectors.
Connectors: X241, X41, BR4 (Hold the clip to remove.)
NOTE
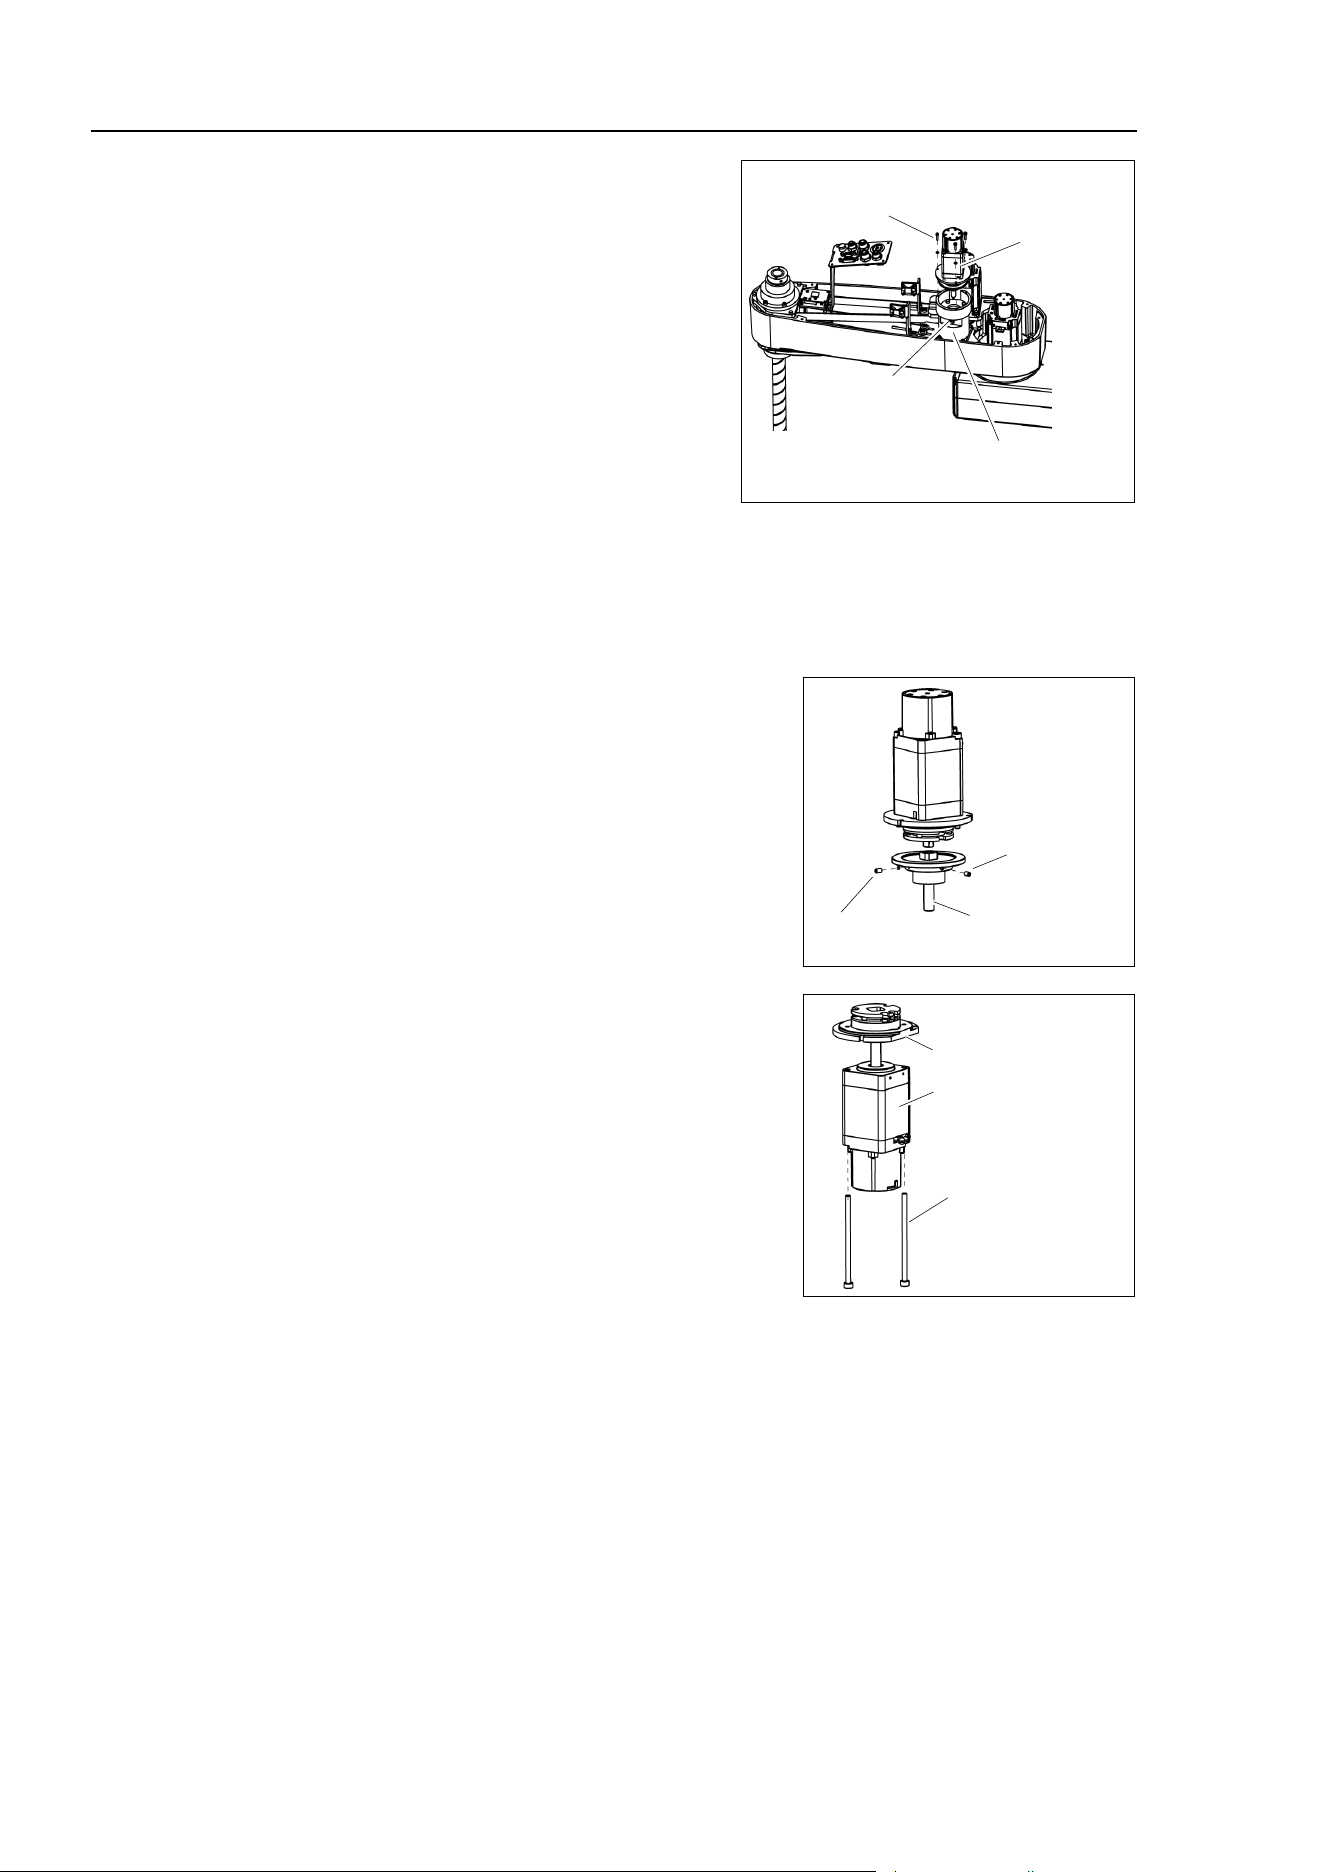
Maintenance 8. Joint #4
126 L
S20-B Rev.4
(8)
Remove the
screws mounting Joint #4
motor unit
on the reduction gear unit.
Joint #4
Motor Unit
3-M3×12
+Plain Washer
Hole for fixing the
extension shaft
Joint #4
Reduction Gear Unit
(9)
Remove the cover of the hole for fixing the
extension
shaft on the side of the reduction
gear,
and loosen the screws.
If the screw position
does not match, turn
the motor slightly and
move until the screw
fixing the
extension shaft can be seen.
(1
0)
Remove Joint #4 motor unit from the reduction gear unit.
(1
1)
Mount the cover of
the hole for fixing the extension shaft on the side of reduction
gear unit.
(1
2)
Pull the moto
r unit upward to remove.
(1
3)
Loosen the set screws tightening
the extension
shaft and remove the shaft from
the Joint #4
motor unit.
There is a brass
bushing in one of the set screw
holes.
Be sure to keep the bushing.
M3×5 Set Screw
+ M3 Bushing
Extension Shaft
M3×5
Set Screw
(1
4)
Remove
the Joint #4 motor from the motor plate.
2-M4×70
Joint #4 Motor
Motor Plate
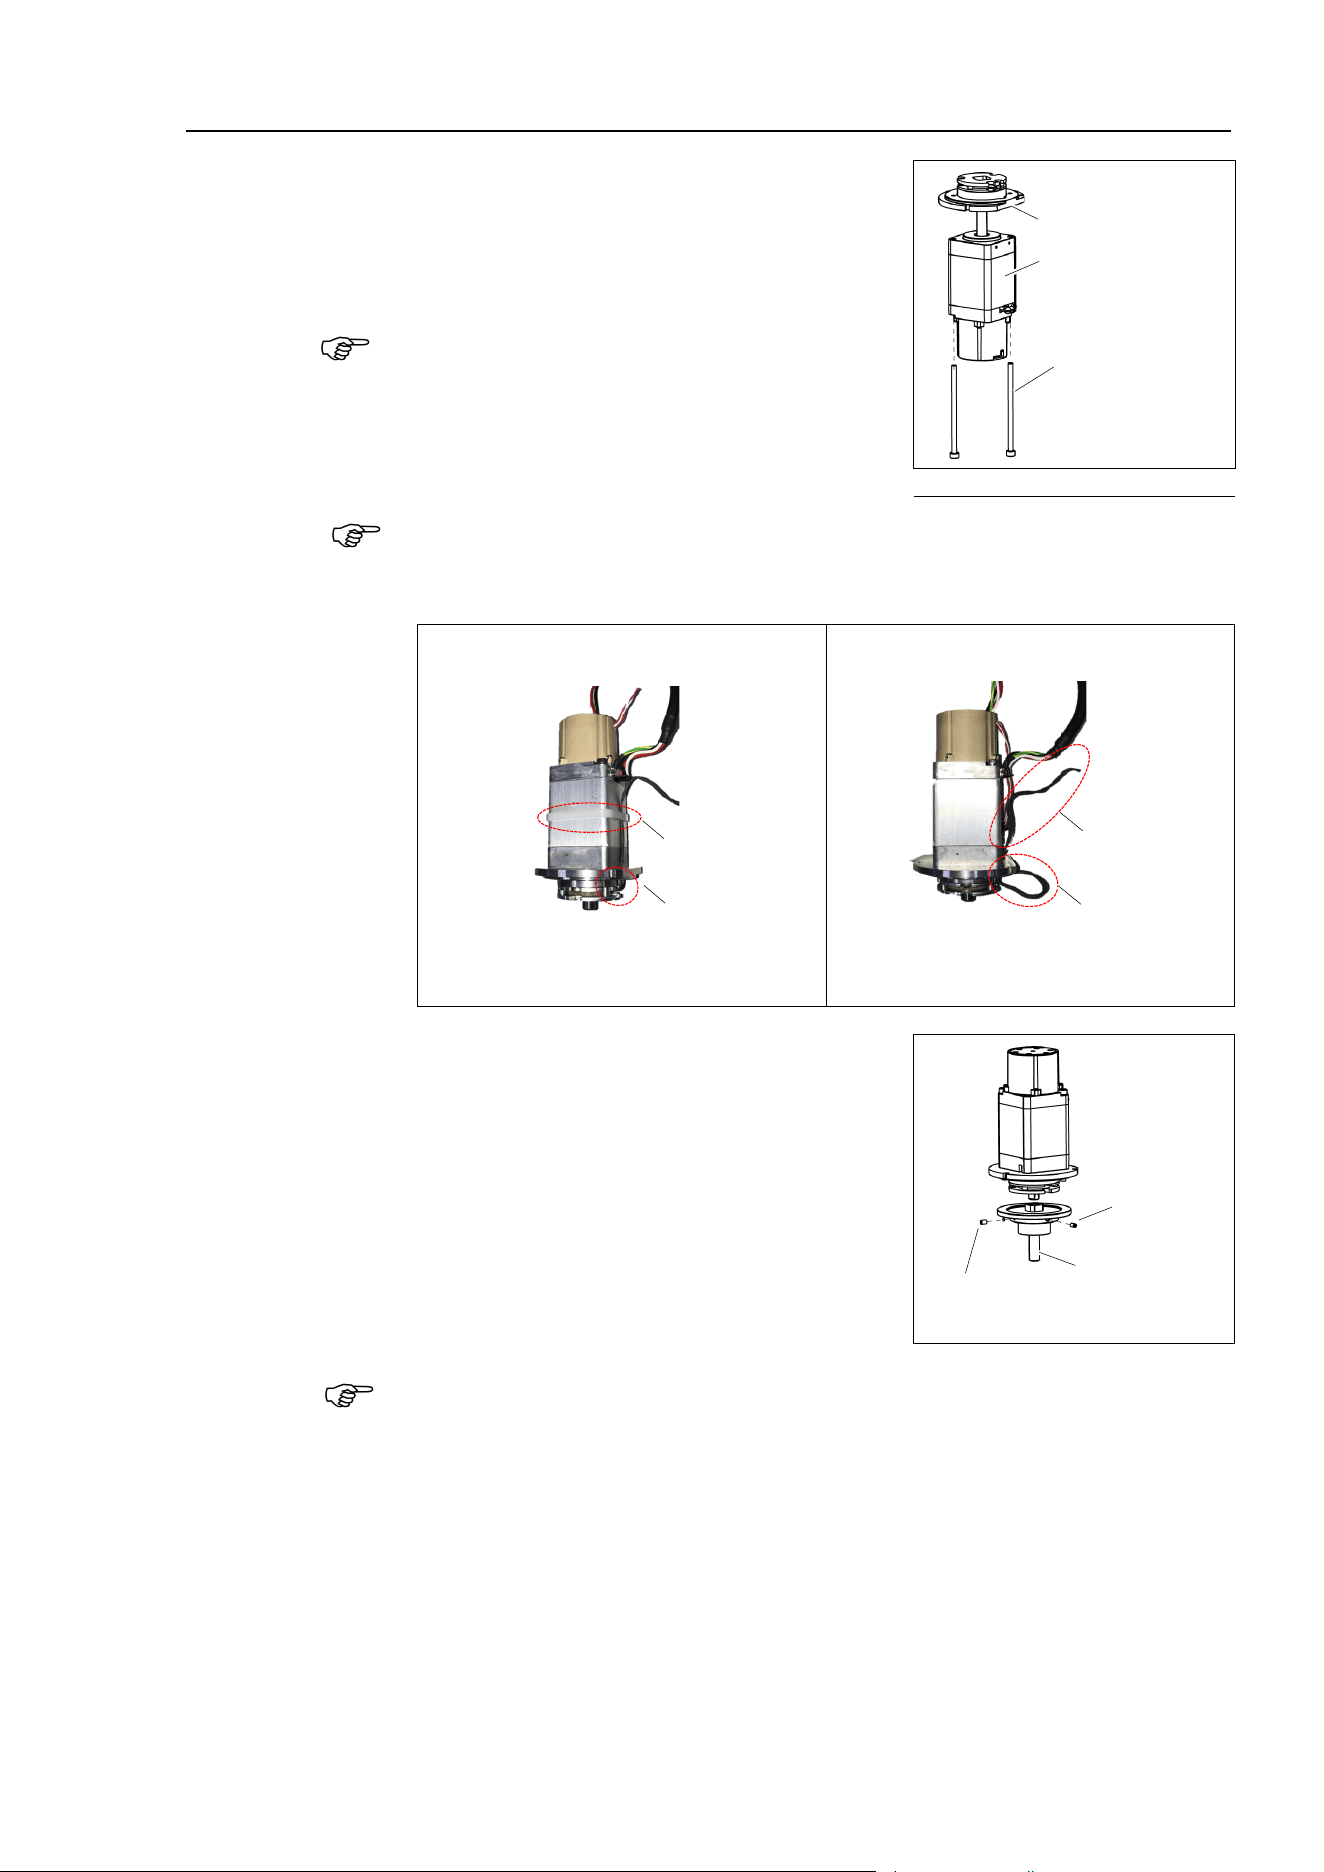
Maintenance 8. Joint #4
LS20-B Rev.4 127
Joint #4 motor
Installation
(1)
Mount the Joint #4 motor on
the motor plate.
Before you mount
the motor, make sure that the
brake harness
passes through a gap of the motor
plate.
2-M4×70
Joint #4 Motor
Motor Plate
When mounting
the motor, be careful not to catch the brake harness in the space
between
the motor plate and Joint #4 motor.
After the motor is mounted, bind
the
brake harness with a wire tie and fix it on the motor.
Correct Example Wrong Example
(a)
(b)
(c)
(d)
(a) The brake harness is fixed to the motor with
the attached wire tie.
(b) The brake harness is not come out.
(c) The brake harness is not fixed to the motor.
(d) The brake harness is come out.
(2)
Mount the
extension shaft on the Joint #4 motor
unit
while aligning the hub of the extension shaft to
the brake disc.
Tighten one of the set screws vertically on the flat
face of the
extension shaft.
Insert a bushing into the other set screw hole to
preven
t damage to the extension shaft.
M3×5 Set Screw
+ M3 Bushing
Extension Shaft
M3×5
Set Screw
When the brake disc is not aligned, manually adjust the position by following the
steps
below.
1. Connect the connector: BR4.
2. Press the brake release switch to release the brake.
3. Manually adjust the brake disc so that the hole will be at the center.
NOTE
NOTE
NOTE
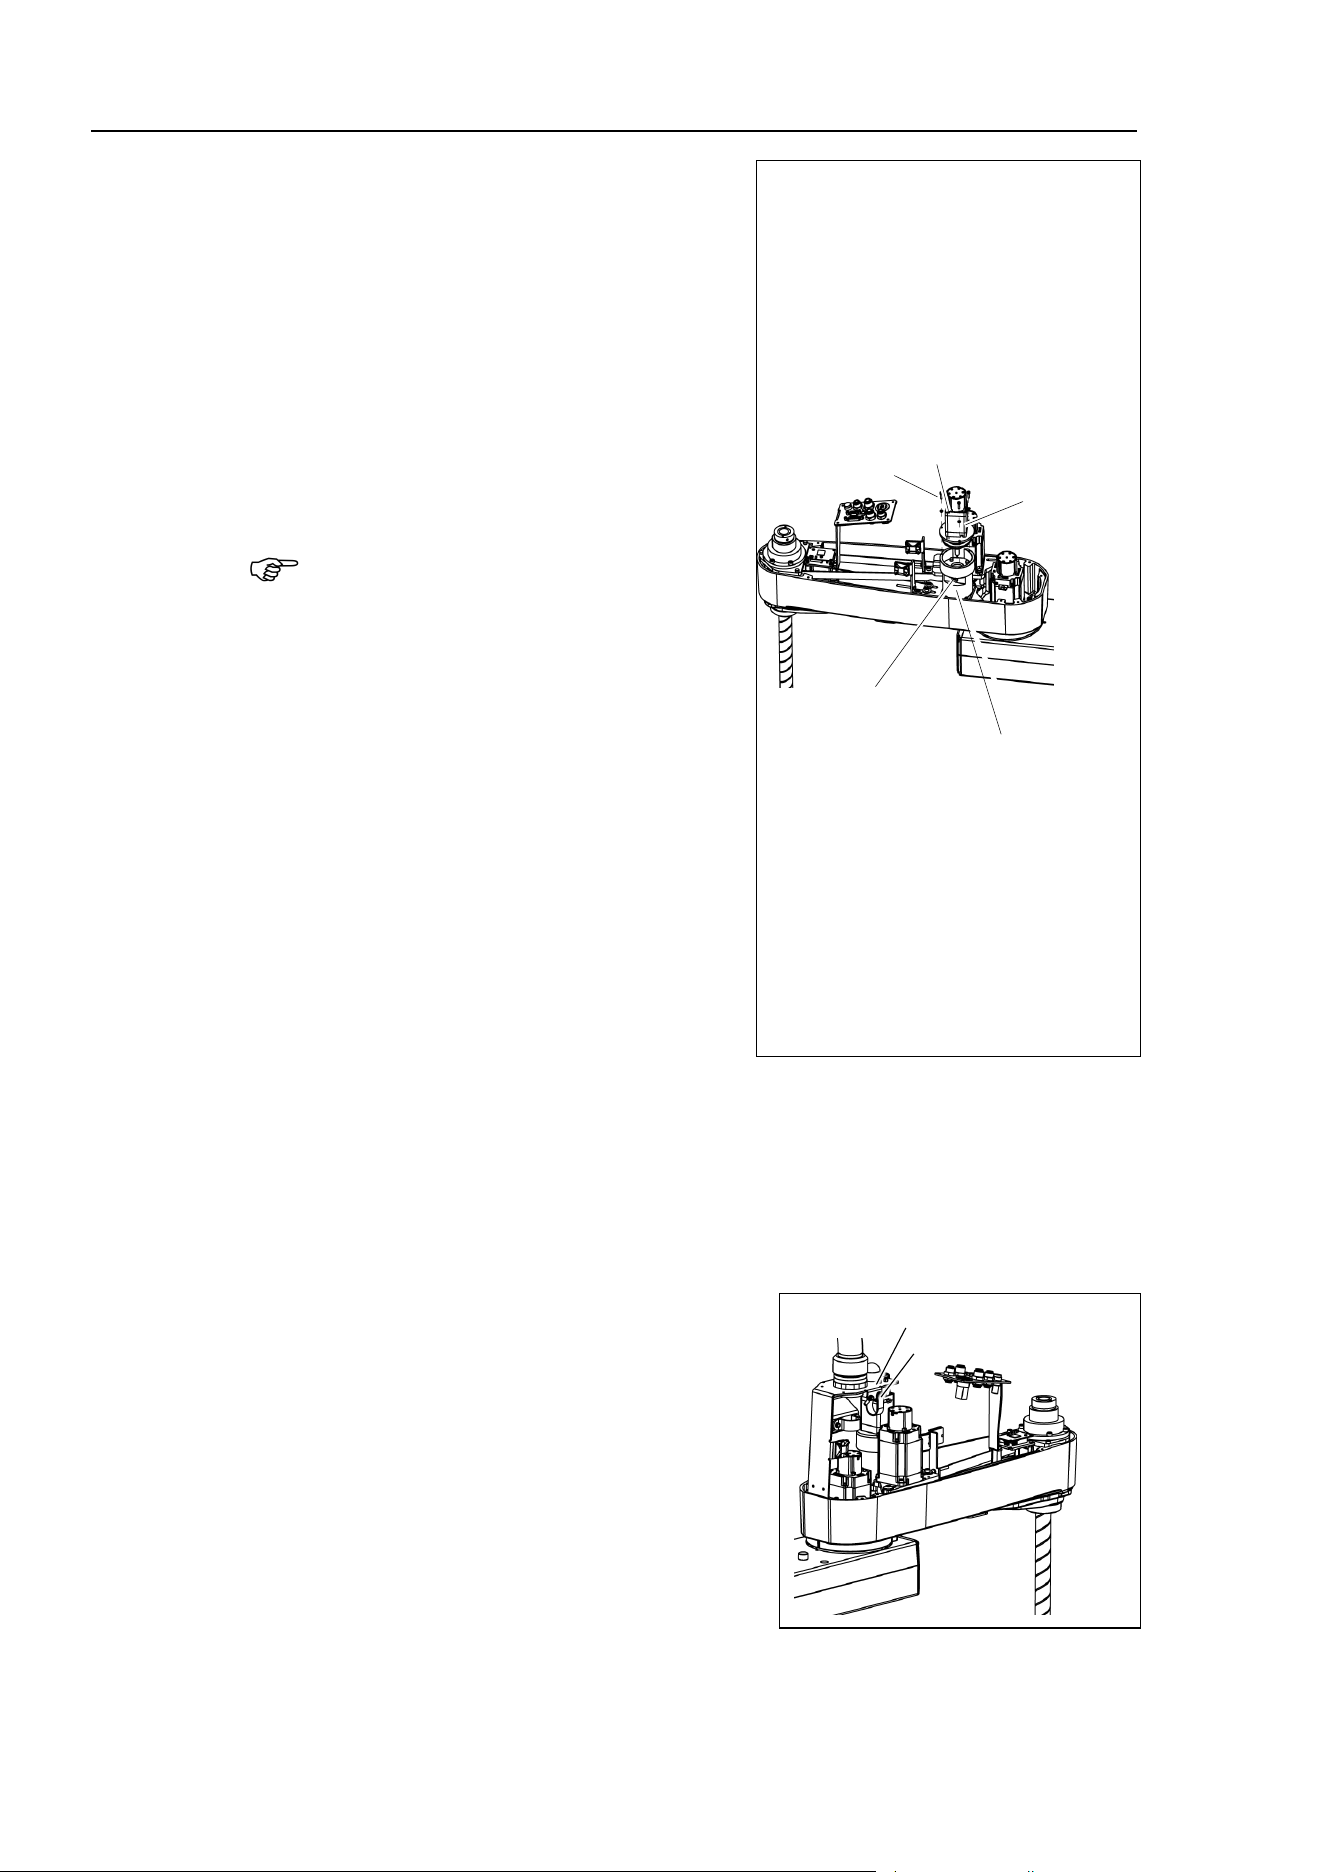
Maintenance 8. Joint #4
128 L
S20-B Rev.4
(3)
Insert the extension shaft to the reduction
gear unit.
M
ake sure that Joint #4 motor cable is
sideways when
looking from the front side
of Arm #2.
After
inserting the extension shaft, loosely
secure the motor plate on
the Joint #4 motor
unit with
bolts (M3×12)
, and loosen the
motor fixing
bolts (M4×70) to secure the
motor loosely.
At this point, m
ake sure that the motor unit
can be moved by hand, and it will not tilt
when pulled.
Before fixing it to the reduction gear unit,
make sure to rotate Joint #4 reduction unit
two or three times from the output side
by
tu
rning shaft or belt.
Remove the cover
of the hole for fixing the
extension shaft
, and then tighten the bolts to
fix
the extension shaft on the reduction gear
unit.
Joint #4
Motor Unit
3-M3×12
+Plain Washer
Hole for fixing the
extension shaft
Joint #4
Reduction Gear Unit
2-M4×70
(4)
T
ighten the bolts on the loosely secured
motor plate
and the motor to fix Joint #4
motor unit
on the reduction gear unit.
(5)
M
ount the cover of the hole for fixing the extension shaft.
(6)
Connect the following connectors.
C
onnectors: BR4, X241, X41
(7)
M
ount the User Plate and the Duct Plate.
For details, refer to Maintenance 3. Covers.
(8)
Install the clip band removed in the removal
step (5), bind the cables, and then fix
them.
Do not
bend or pull the cables forcibly to allow
unnecessary strain on the cables.
Clip Band
Duct Plate
(9)
Mount
the Arm Top Cover.
For details, refer to Maintenance: 3.1 Arm Top Cover.
NOTE
Maintenance 8. Joint #4
L
S20-B Rev.4 129
(10)
Check if the Joint #
4 moves in a Jog motion by operating from EPSON RC+ menu
-
[Tools]
-[Robot Manager]-[Jog & Teach].
If the Manipulator oscillates with
MOTOR ON and the following errors are detected,
Error 5041: Motor torque output failure in low power state.
Error 4241: Over speed during low power mode was detected.
or when the joint other than Joint #
4
moves, the connector for other joint might be
connected to the Joint #
4 motor. Check the connector connection.
(11)
Execute the calibration of Joint #4.
F
or details, refer to Maintenance: 13. Calibration.
Maintenance 8. Joint #4
130 L
S20-B Rev.4
8.2 Replacing the Timing Belt
Name Qty. Note
Maintenance
part
U belt (width 30 mm) 1
1618729
Tools
Hexagonal
wrench
width across flats: 3 mm 1 For M4 screw
width across flats: 4 mm
1
For M5 screw
Spanner
width across flats: 7 mm 1
Cross-point screwdriver (#2)
1
For M3, M4 screws
Torque wrench
1
Nippers
1
For cutting wire tie
Sonic tension meter
1
Z: Tension 206 N (21.0 ± 0.75 kgf)
Material
Wire tie
-
For binding cables
A brake is mounted on the motor of Joints #3 and #4 to prevent the shaft from moving down
and rotating due to the weight of the end effector while the power to the Controller is OFF
or while the motor is in OFF status (MOTOR OFF).
Move the shaft down to its lower limit before the replacement procedure following the
removal steps.
NOTE
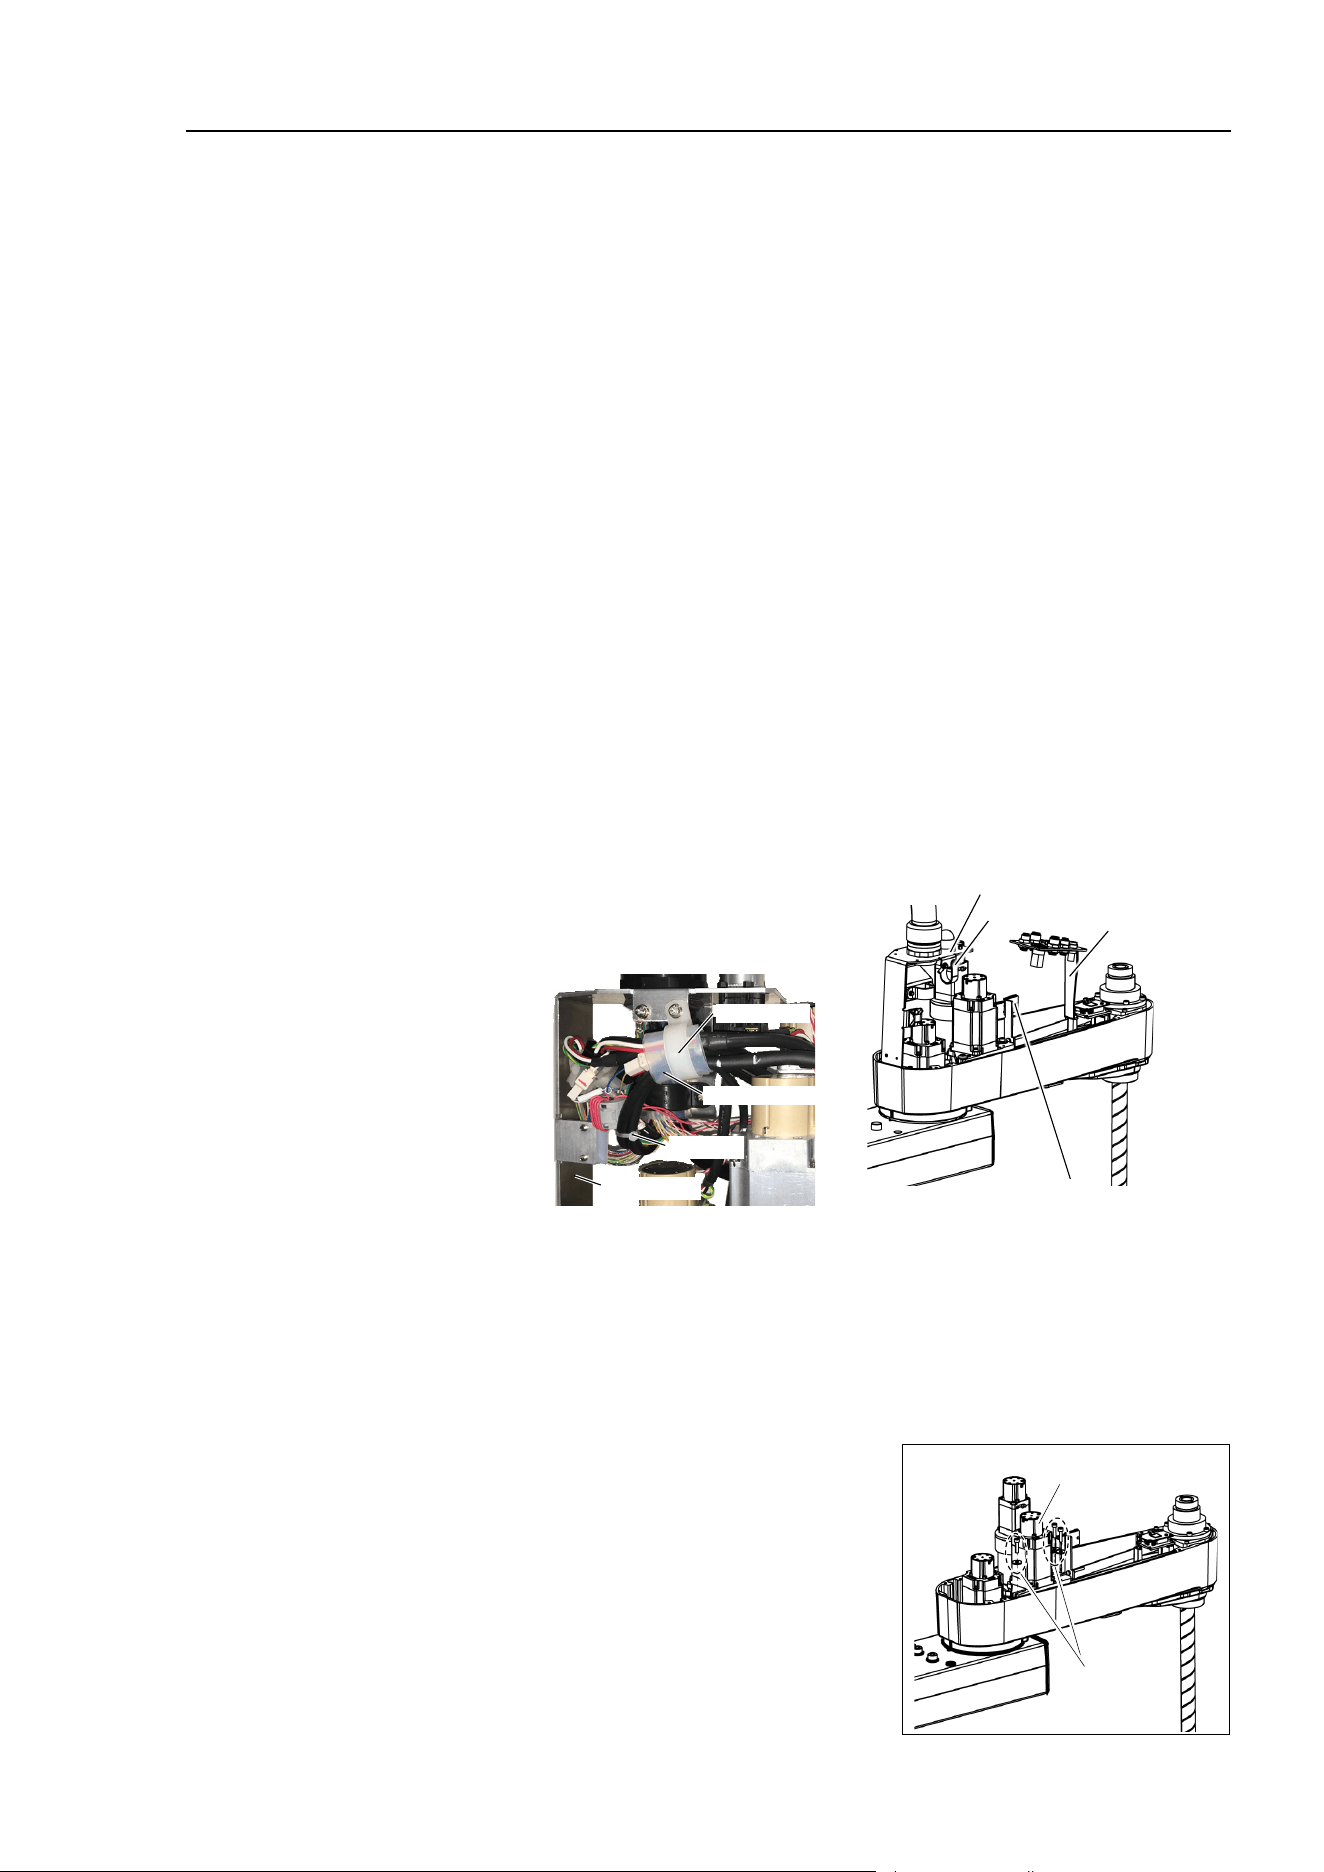
Maintenance 8. Joint #4
LS20-B Rev.4 131
U belt
Removal
(1)
Turn ON the Controller.
(2)
Push down the shaft to its lower limit while pre
ssing the brake release switch.
Be sure to keep enough space and prevent
the end effector hitting any
peripheral
equipment.
The brake release switch is applied to both Joints #3 and Joint #4.
When the brake
release switch is pressed, the respective brakes of the Joint #3 and Joint #4 are released
simultaneously.
Be careful of the
shaft falling and rotating while the brake release switch is
being
pressed
because the shaft may be lowered by the weight of an end effector.
(3)
Turn OFF the Controller.
(4)
Remove the
Arm Top Cover.
For details, refer to Maintenance: 3.1 Arm Top Cover.
(5)
Remove the clip band and
sheet bundling the motor cables.
Cut off the wire tie fixing the cable
s to the belt tensioner.
D
o not cut the wire tie (in the duct fittings outlet) that binds the cables to the duct
plate.
Removed parts
will be used again. Be careful not to lose them.
Clip Band
Wire Tie
Duct Plate
Silicon Sheet
Clip Band
Duct Plate
User Plate
Belt Tensioner
(6)
Dis
connect the following connectors.
Connectors: X231, X241, X43, X44, X51, BR3, BR4
(Hold the clip to remove.)
(7)
Remove
the User Plate and the Duct Plate.
For details
, refer to Maintenance 3. Covers.
(8)
Remove the screws
mounting the Joint #3 motor
unit
.
Remove
the Joint #3 motor from the motor plate
and pull out the Z belt.
For details, refer to Maintenance 7.2. Timing
Belt.
Joint #3
Motor Unit
3-M5×20
+ washer for
slotted hole
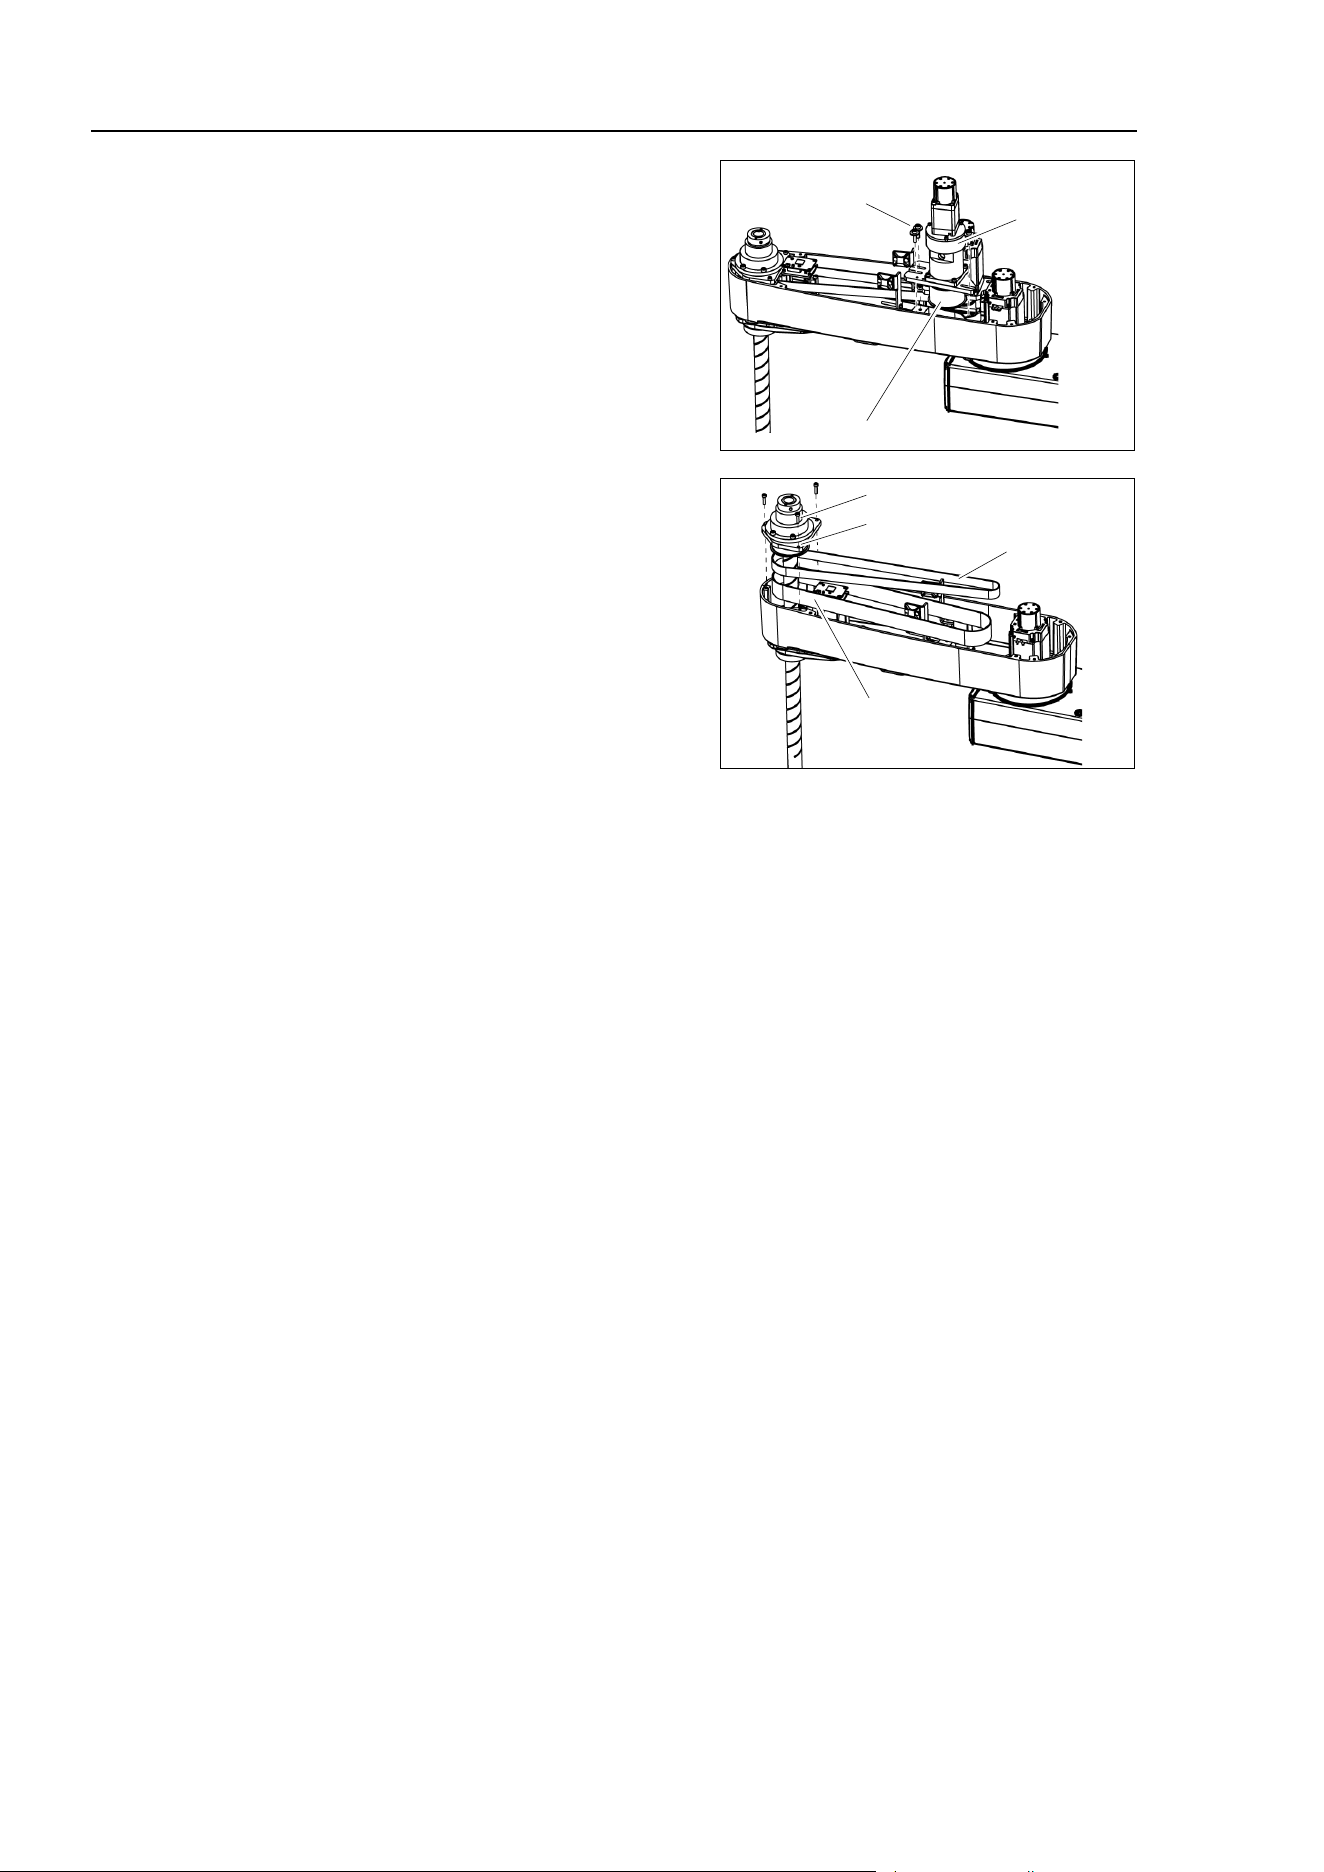
Maintenance 8. Joint #4
132 L
S20-B Rev.4
(9)
Remove the screws
mounting the Joint
#
4 motor unit.
Pull the Joint #4 motor unit upward
.
Joint #4
Motor Unit
3-M3×12
+ Plain Washer
Joint #4
Reduction Gear Unit
(10)
Remove the screws mounting the spline
plate.
Hold up the spline plate and pull out the
Z
belt and U belt.
3-M4×15
Spline Plate
Z Belt
U Belt
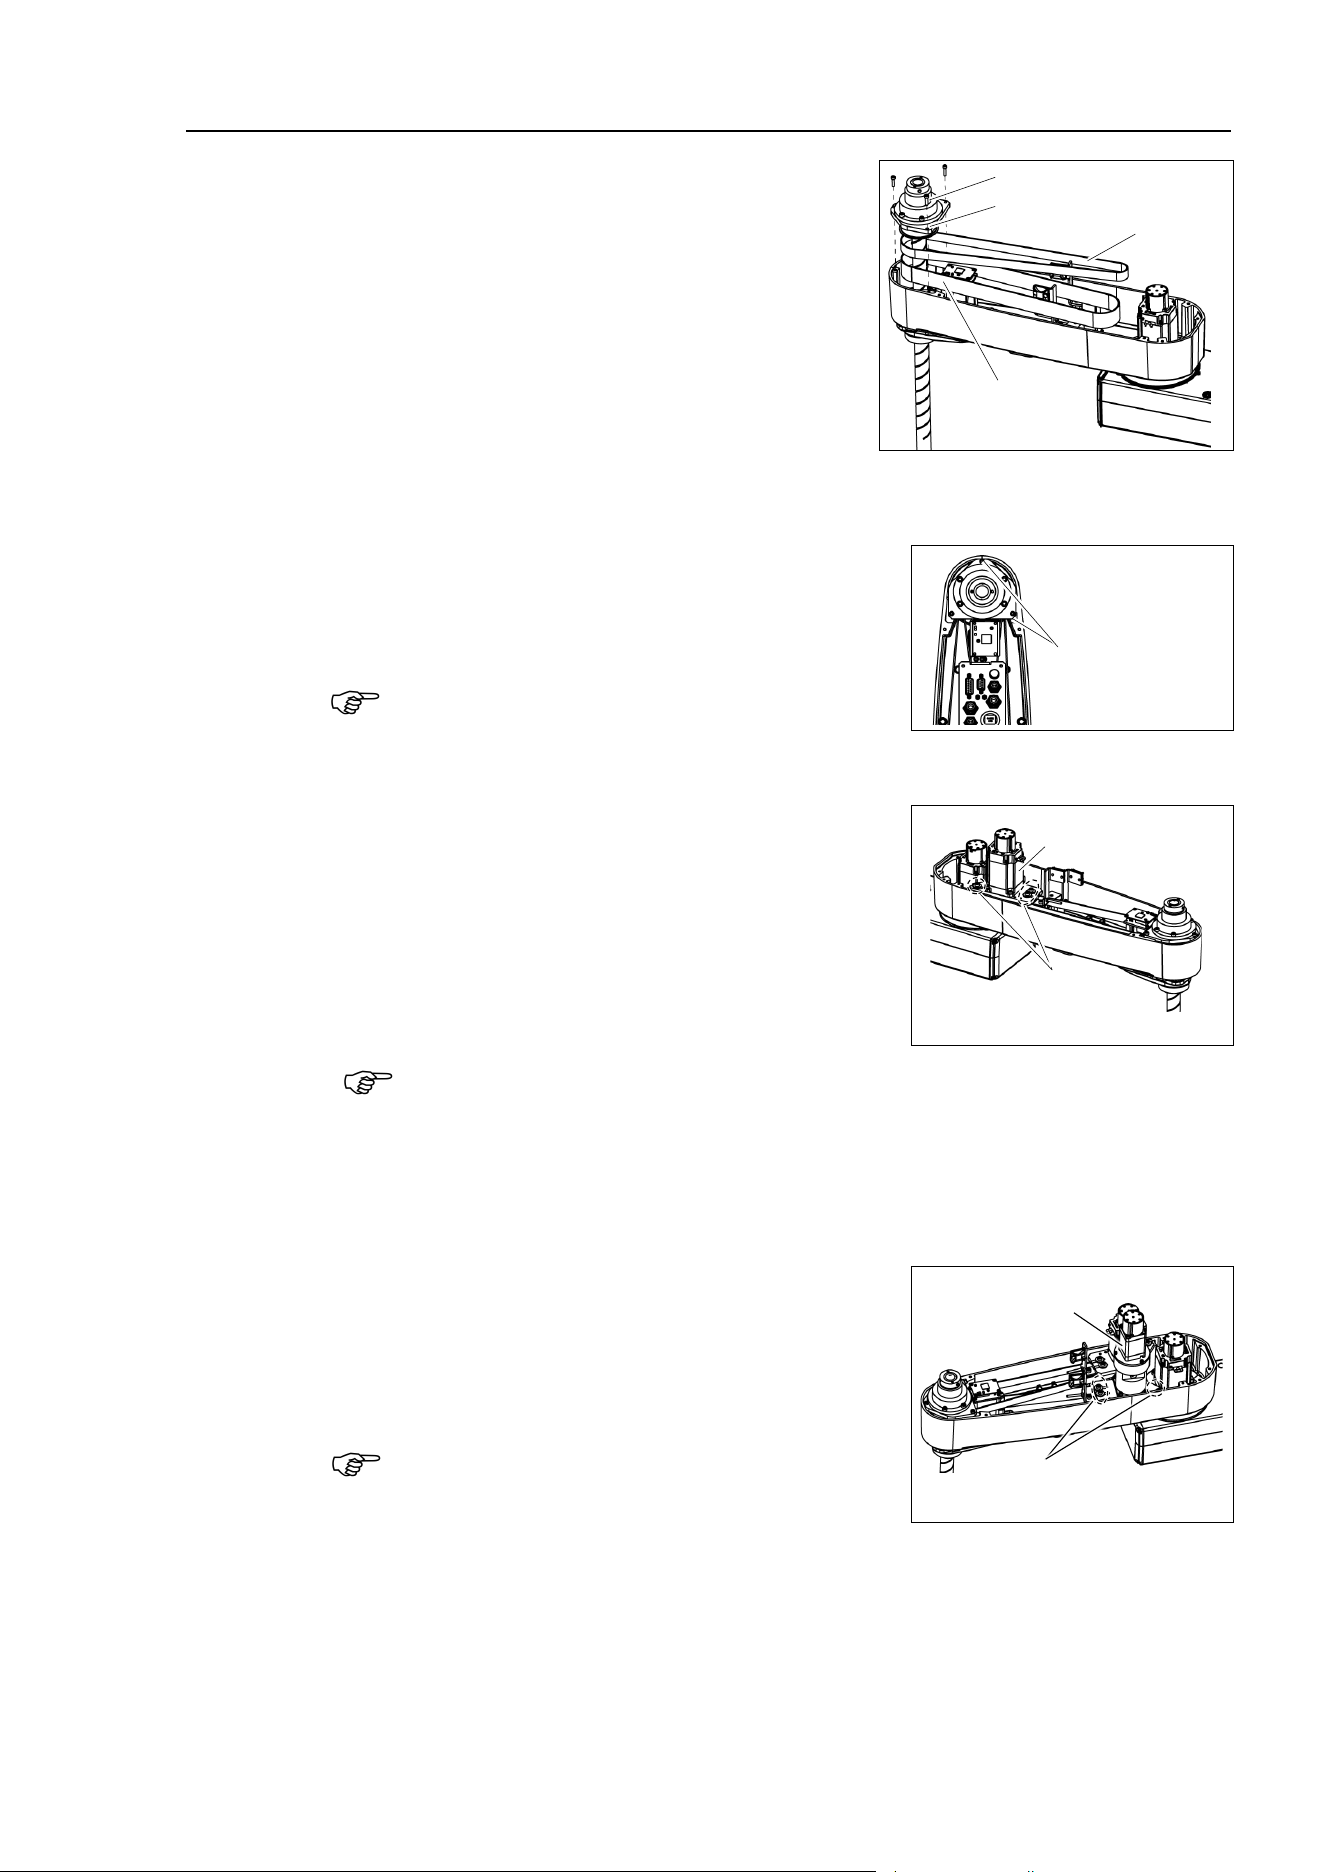
Maintenance 8. Joint #4
LS20-B Rev.4 133
U
belt
Installation
(1
)
Hold up the spline plate and set the U belt
around the pulley.
Make sure the gear grooves of the belt are
fit
into those of the pulleys completely.
3-M4×15
Spline Plate
Z Belt
U Belt
(2)
Hold up the spline plate and set the Z belt
around the Z pulley.
Make sure the teeth of the timing belt are
engaged with those of the pulley.
(3)
Loosely secure the spline plate on the
Arm #2 and
move the shaft up and down
several times before
firmly secure the
spline plate.
Loosely tighten
the screws so that the spline plate
can be moved by
hand. Fix the spline plate with
the screws while
pushing the front side of the Arm
#2 and
the right side face.
Faces to push
the spline plate
(4)
Loosely secure the Joint #3 motor unit to
the Arm
#2.
Make sure the teeth of the
timing belt are engaged
with those of the pulley.
Joint #3
Motor Unit
3-M5×20
+washer for
slotted hole
At this point, make sure that the Joint #3 motor unit can be moved by hand, and it
will not tilt when pulled.
If the unit is tilted, the belt will not have the proper tension.
(5)
A
pply the proper tension to the Z belt, and then secure the Joint #3 motor unit.
For details, refer to Maintenance: 7.2 Replacing the Timing Belt.
(6)
Loosely secure the Joint #4 motor unit to
the Arm
#2.
Make sure the
teeth of the timing belt are engaged
with those of the pulley.
M
ake sure that the Joint #4 motor unit can be
moved by hand, and it
will not tilt when pulled.
3-M5×20
+ washer for slotted hole
Joint #4
Motor Unit
If the unit is tilted, the belt will not have the proper
tension.
NOTE
NOTE
NOTE
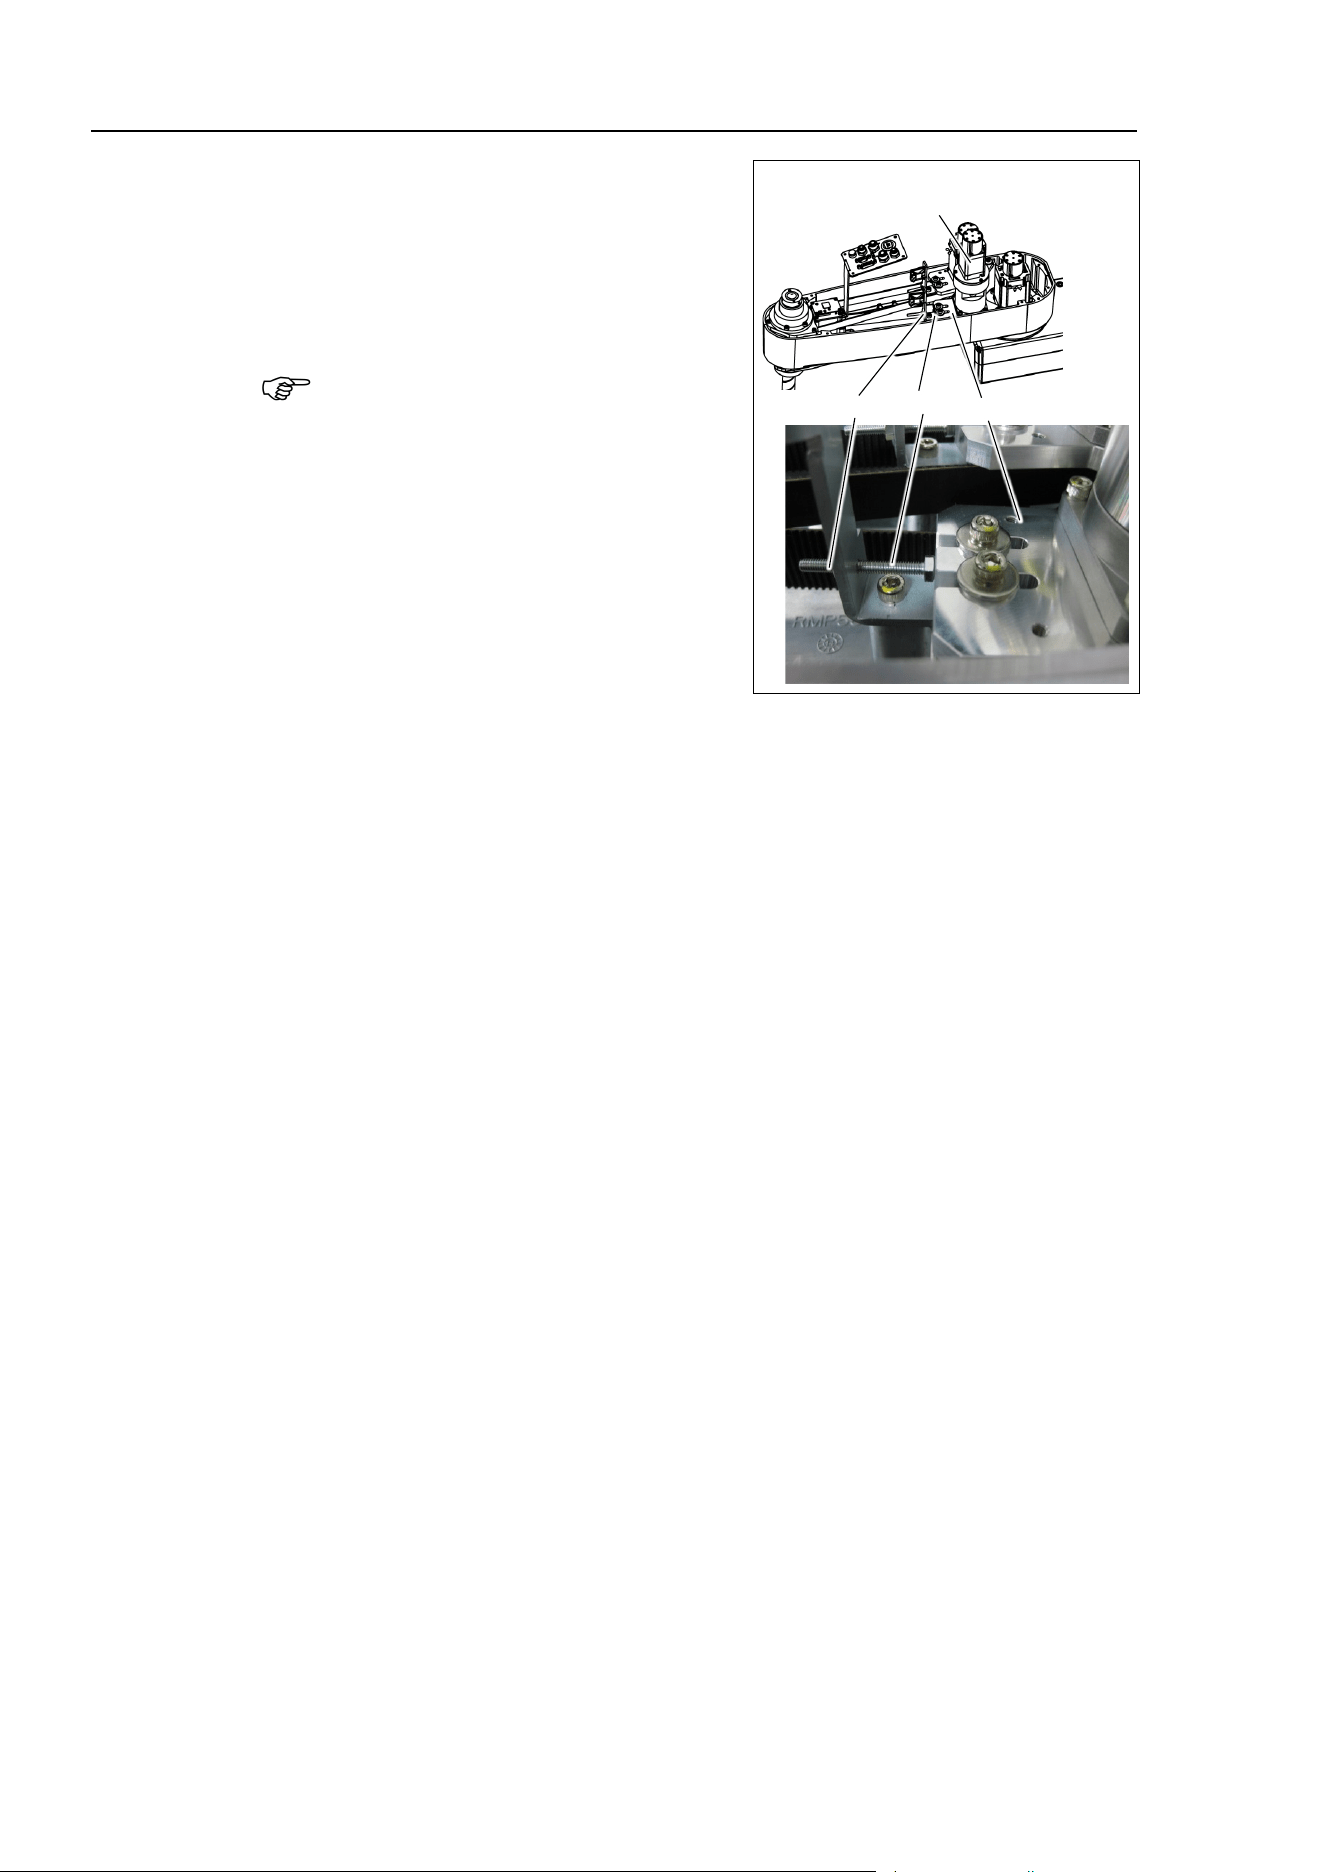
Maintenance 8. Joint #4
134 L
S20-B Rev.4
(7)
Apply the proper tension to the U belt,
and
then secure the Joint #4 motor unit.
U
belt tension
: 206 N (21.0 ± 0.75 kgf)
Axial tension (when being pulled): 412 N
T
o apply tension to the Joint #4 motor unit,
use the bolt at
the front of the plate.
M4 Bolt
Joint #4
Motor Unit
Plate
M4 Nut
(7)
-1
Loosen the nut and turn the bolt.
Push in the Joint #4 motor unit
plate
slowly.
(7)
-2
After fixing the Joint #4 motor
unit,
turn the bolt to leave from
the plate.
(7)
-3
Check the
tension using the sonic tension meter.
For details, refer to Maintenance 8.5 Checking the Timing Belt Tension.
(7)
-4
Repeat the steps (7)
-1 through (7)-3 until you get appropriate tension.
(7)
-5
After the adjustment, put the bolt back to its
original position and fix it with
the nut.
(8)
Connect the following connectors
.
Connectors: X231, X241, X43, X44, X51, BR3, BR4
(9)
M
ount the User Plate and the Duct Plate.
For details, refer to Maintenance 3. Covers.
(10)
Bind the cables with
new wire ties at their original positions as before in the removal
step (5).
Bind the cables with the clip band.
Do not allow unnecessary strain on
the cables.
(11)
Install
the Arm Top Cover.
For details, refer to Maintenance: 3.1 Arm Top Cover.
(12)
Check if the Joint
s #3, #4
moves in a Jog motion by operating from EPSON RC+ menu
-
[Tools]-[Robot Manager]-[Jog & Teach].
If the Manipulator oscillates with MotorON and the following errors are detected,
E
rror 5041: Motor torque output failure in low power state.
Error 4241: Over speed during low power mode was detected.
or when the joint other than Joint
s #3, #4
moves, the connector for the other joint might
be
connected to the Joints #3, #4 motor. Check the connector connection.
(13)
Execute the calibration for Joint #3, 4.
F
or details on the calibration method, refer to Maintenance: 13. Calibration.
NOTE
Maintenance 8. Joint #4
LS20-B Rev.4 135
8.3 Replacing the Brake
Name Qty. Note
Maintenance
part
Electromagnetic brake 1 1803965
Tools
Hexagonal
wrench
width across flats: 1.5 mm 1 For M3 set screw
width across flats: 3 mm
1
For M4 screw
width across flats: 4 mm 1 For M5 screw
Spanner
width across flats: 7 mm
2
For M4 bolt, M4 nut
Cross-point screwdriver (#2) 1 For M4 screw
Torque wrench
1
A brake is mounted on the motor of Joints #3 and #4 to prevent the shaft from moving down
and rotating due to the weight of the end effector while the power to the Controller is OFF
or while the motor is in OFF status (MOTOR OFF).
Move the shaft down to its lower limit before the replacement procedure following the
removal steps.
NOTE
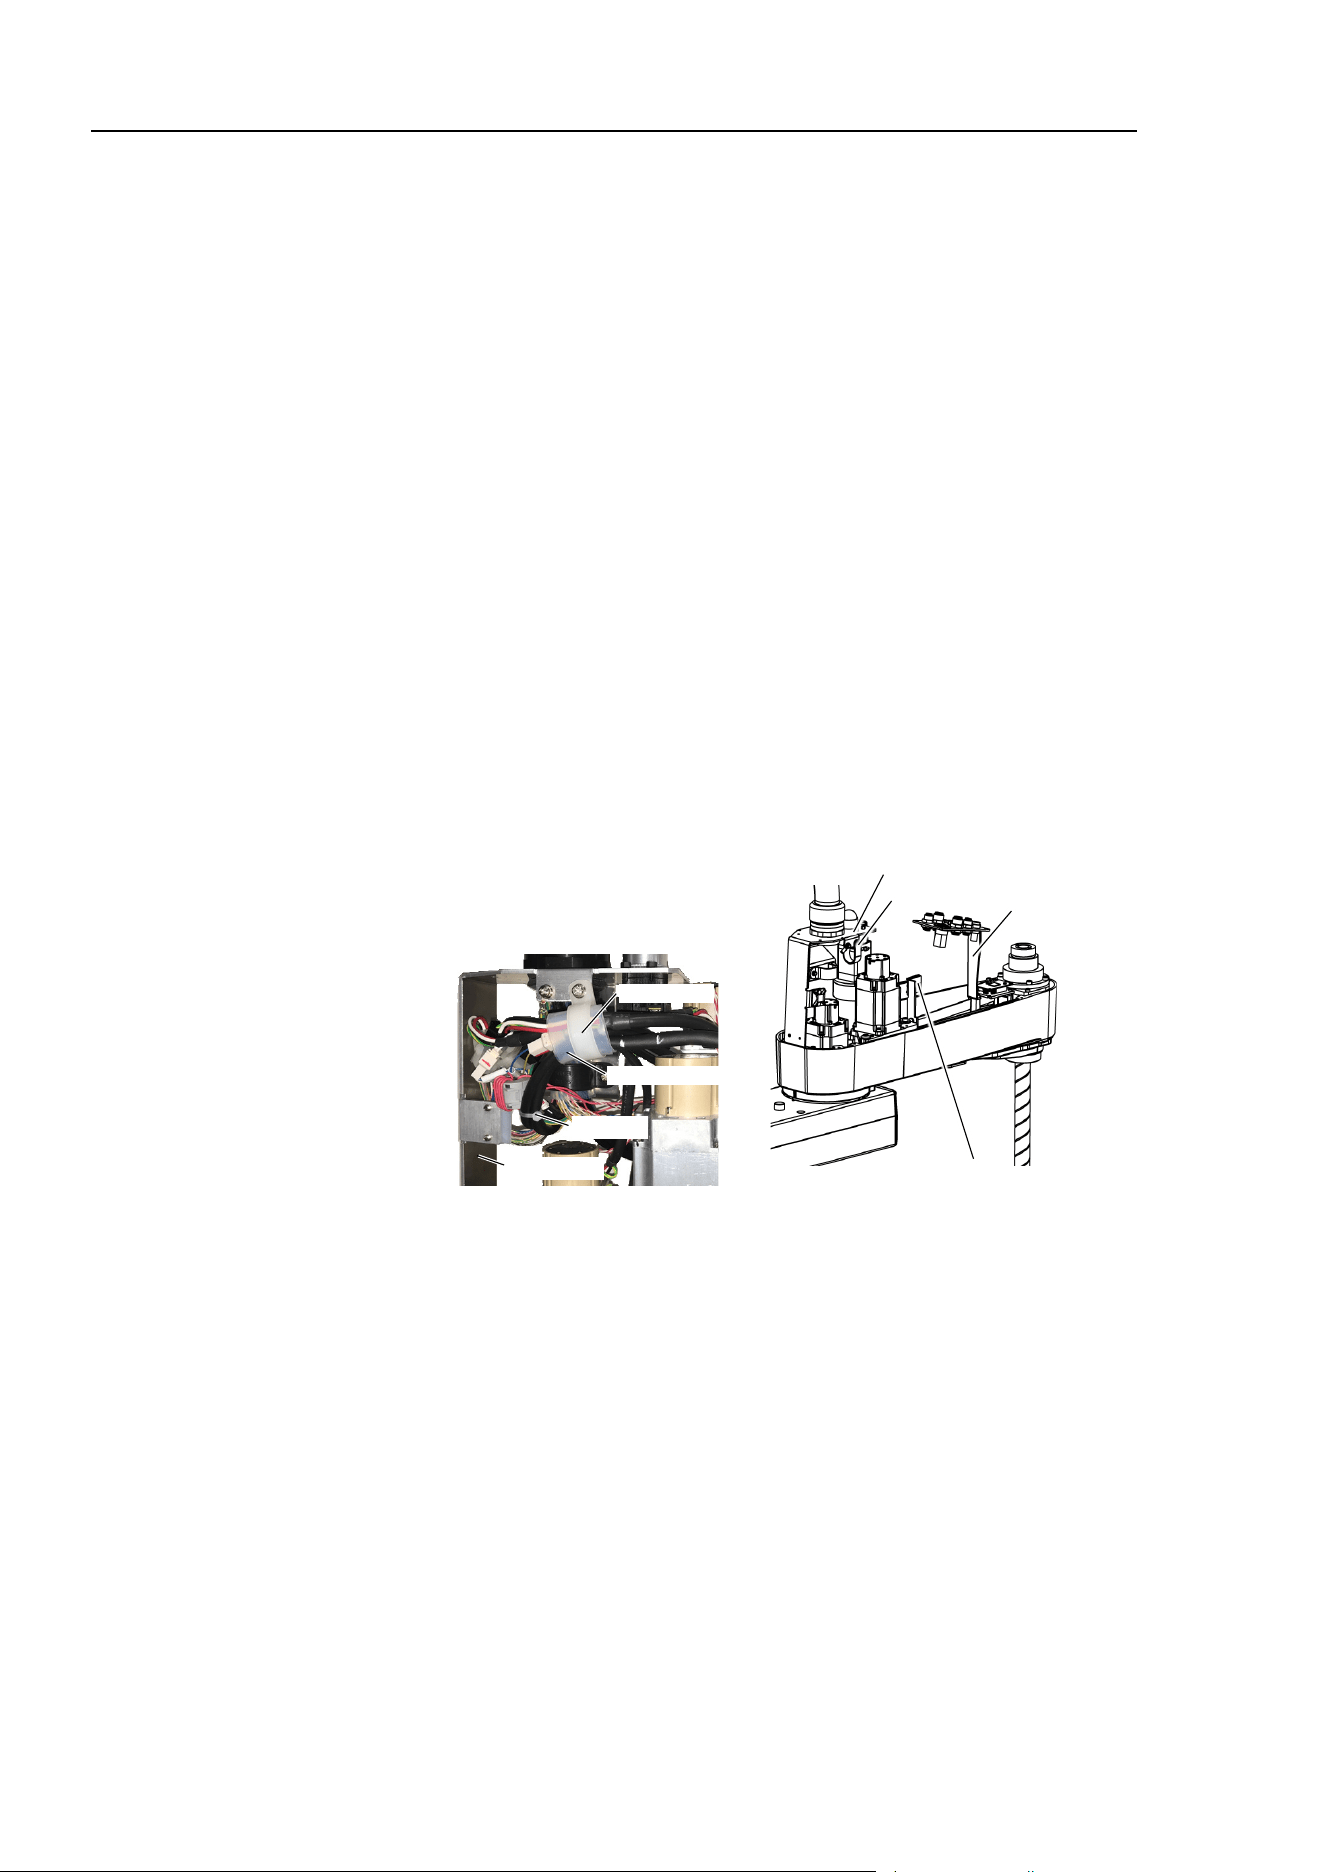
Maintenance 8. Joint #4
136 L
S20-B Rev.4
J
oint #4 Brake
Removal
(1)
Turn ON the Controller
(2)
Push down the shaft to its lower limit while pressing the brake release switch.
Be
sure to keep enough spa
ce and prevent the end effector hitting any peripheral
equipment.
The brake release switch is applied to both Joint #3 and #4.
When the brake release
switch is pressed, the respective brake for Joints #3 and #4 are released
simultaneously.
Be careful of the shaft falling and rotating while the brake release switch is being
pressed because the shaft may be lowered by the weight of an end effector.
(3)
Turn OFF the Controller.
(4)
Remove the Arm Top Cover.
F
or details, refer to Maintenance: 3.1 Arm Top Cover.
(5)
Remove the clip band and
sheet bundling the motor cables.
Cut off the wire tie fixing the cable
s to the belt tensioner.
D
o not cut the wire tie (in the duct fittings outlet) that binds the cables to the duct
plate.
Removed parts
will be used again. Be careful not to lose them.
Clip Band
Wire Tie
Duct Plate
Silicon Sheet
Clip Band
Duct Plate
User Plate
Belt Tensioner
(6)
Remove the Duct Plate.
F
or details, refer to Maintenance: 3. Covers.
(7)
Dis
connect the following connectors.
Connectors: X241, X41, BR4 (Hold the clip to remove.)
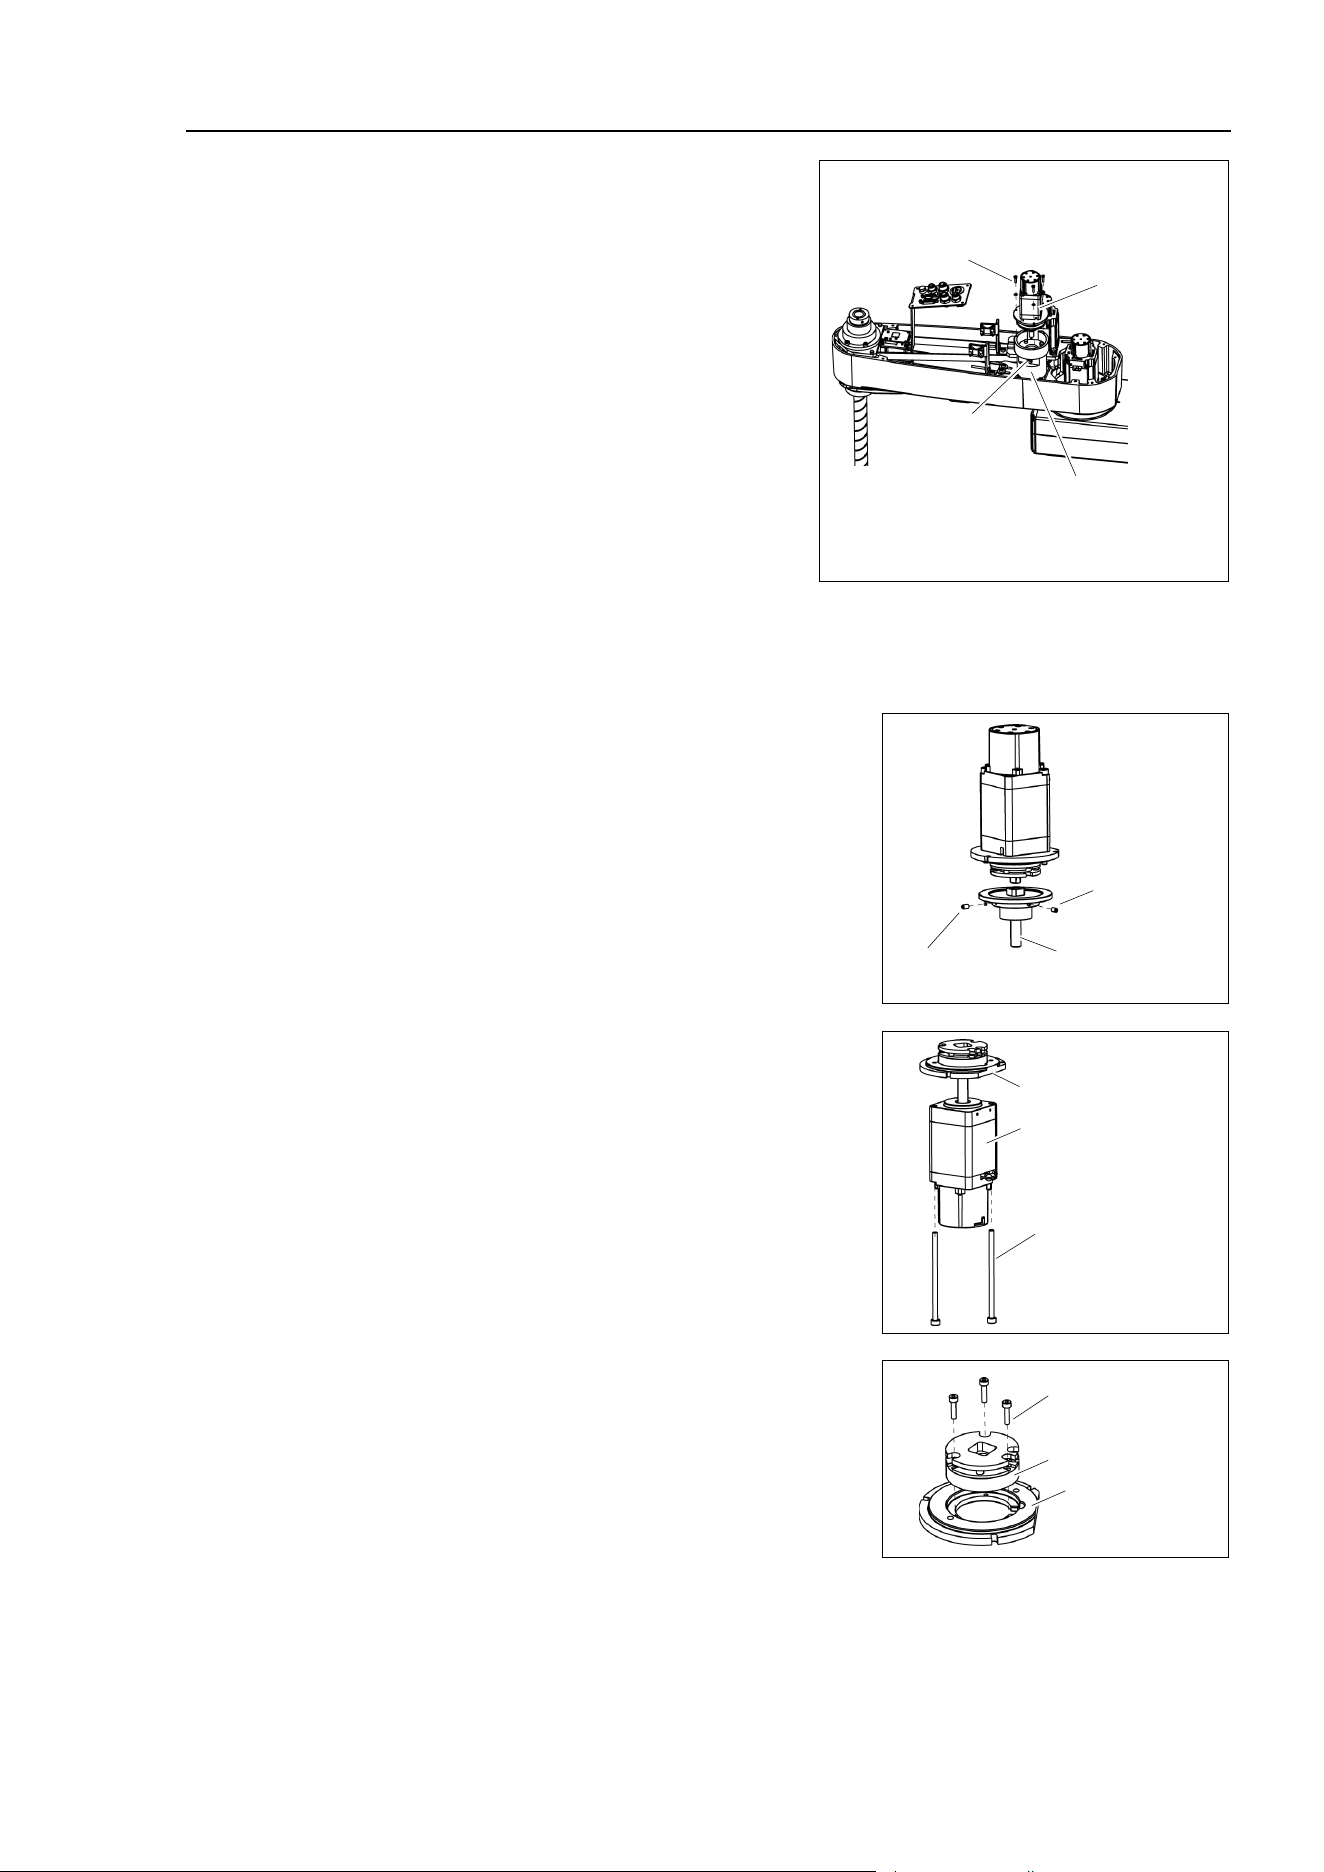
Maintenance 8. Joint #4
LS20-B Rev.4 137
(8)
Remove the screws securing the Joint #4
motor
unit on the reduction gear unit.
Joint #4
Motor Unit
3-M3×12
+ plain washer
Hole for fixing the
extension shaft
Joint #4
Reduction gear unit
(9)
Remove the cover of the hole for fixing
the
extension shaft on the side of the
reduction
gear, and loosen the screws.
If the screw position does not match, turn
the motor
slightly and move until the
screw fixing the
extension shaft can be
seen.
(10)
Remove the J
oint #4 motor unit from the
reduction gear unit.
(11)
M
ount the cover of the hole for fixing the extension shaft on the side of the reduction
gear
.
(12)
Pull the moto
r unit upward to remove.
(13)
Loosen the set screws tightening
the extension
shaft and remove the shaft from
the Joint #4
motor unit.
There is a brass
bushing in one of the set screw
holes.
Be sure to keep the bushing.
(14)
Remove
the Joint #4 motor from the motor
plate.
2-M4×70
Joint #4 Motor
Motor Plate
(15)
Remove the brake from the motor plate.
3-M2.5×10
Joint #4
Motor Plate
Brake
M3×5 Set Screw
+ M3 Bushing
Extension shaft
M3×5
Set Screw
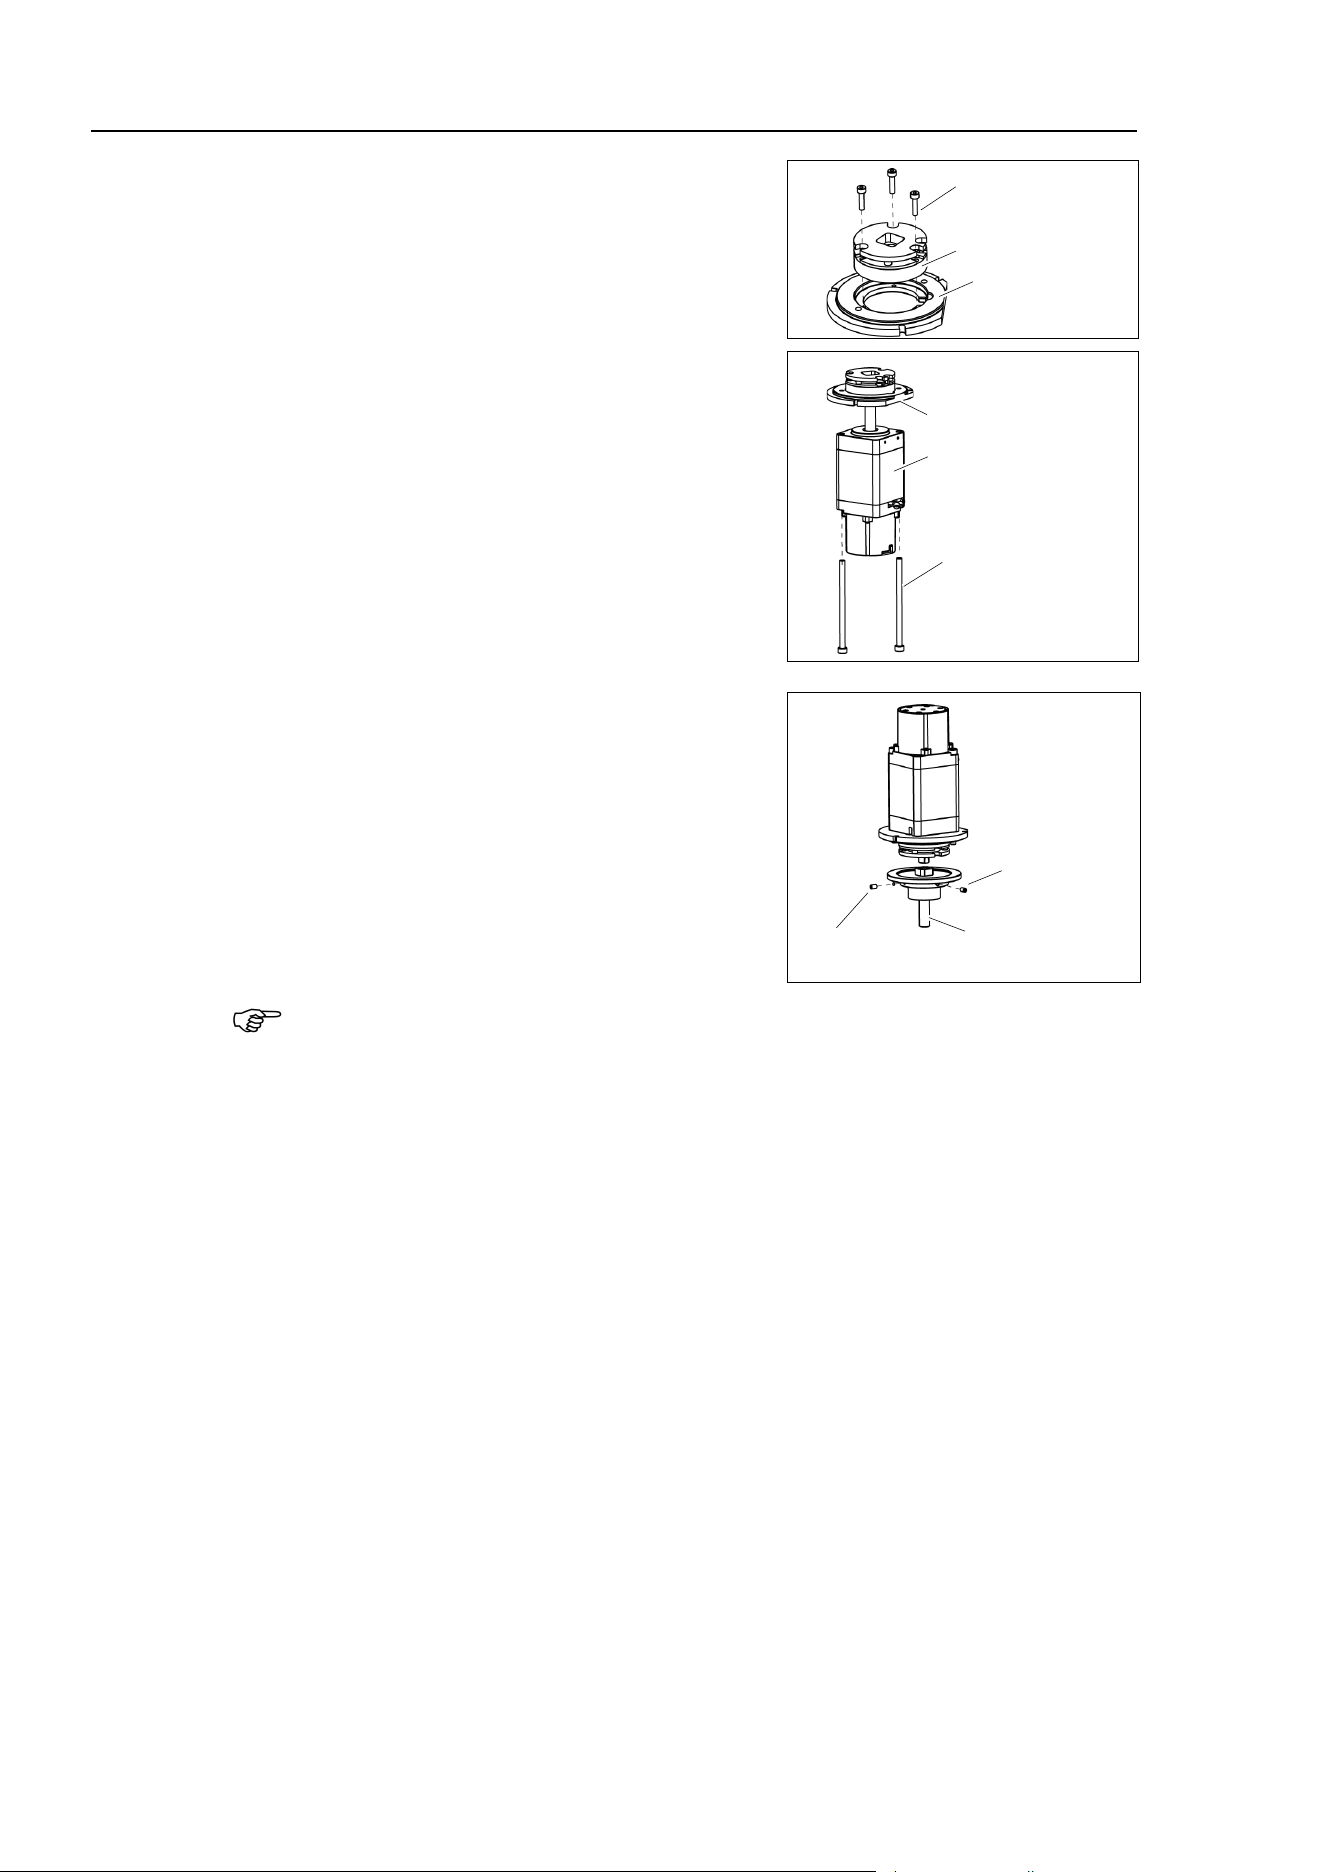
Maintenance 8. Joint #4
138 L
S20-B Rev.4
J
oint #4 Brake
Installation
(1)
Mount
the brake on the motor plate.
3-M2.5×10
Joint #4
Motor Plate
Brake
(2)
Mount the Joint #4 motor on
the motor plate.
Before you mount
the motor, make sure that the
brake harness
passes through a gap of the motor
plate.
When mounting
the motor, be careful not to
catch
the brake harness in the space between the
motor plate
and Joint #4 motor.
After the motor is mounted, bind
the brake
harness with a wire tie and fix it on the motor.
2-M4×70
Joint #4 Motor
Motor Plate
(
3)
Mount the
extension shaft on the Joint #4 motor
unit
while aligning the hub of the extension
shaft
to the brake disc.
Tighten one of the set screws vertically on the
flat
face of the extension shaft.
Insert a bushing into the other set screw hole to
prevent damage to the
extension shaft.
M3×5 Set Screw
+ M3 Bushing
Extension shaft
M3×5
Set Screw
When the brake disc is not aligned, manually adjust the position by following the
steps
below.
1. C
onnect the connector: BR4.
2.
P
ress the brake release switch to release the brake.
3. M
anually adjust the brake disc so that the hole will be at the center.
NOTE
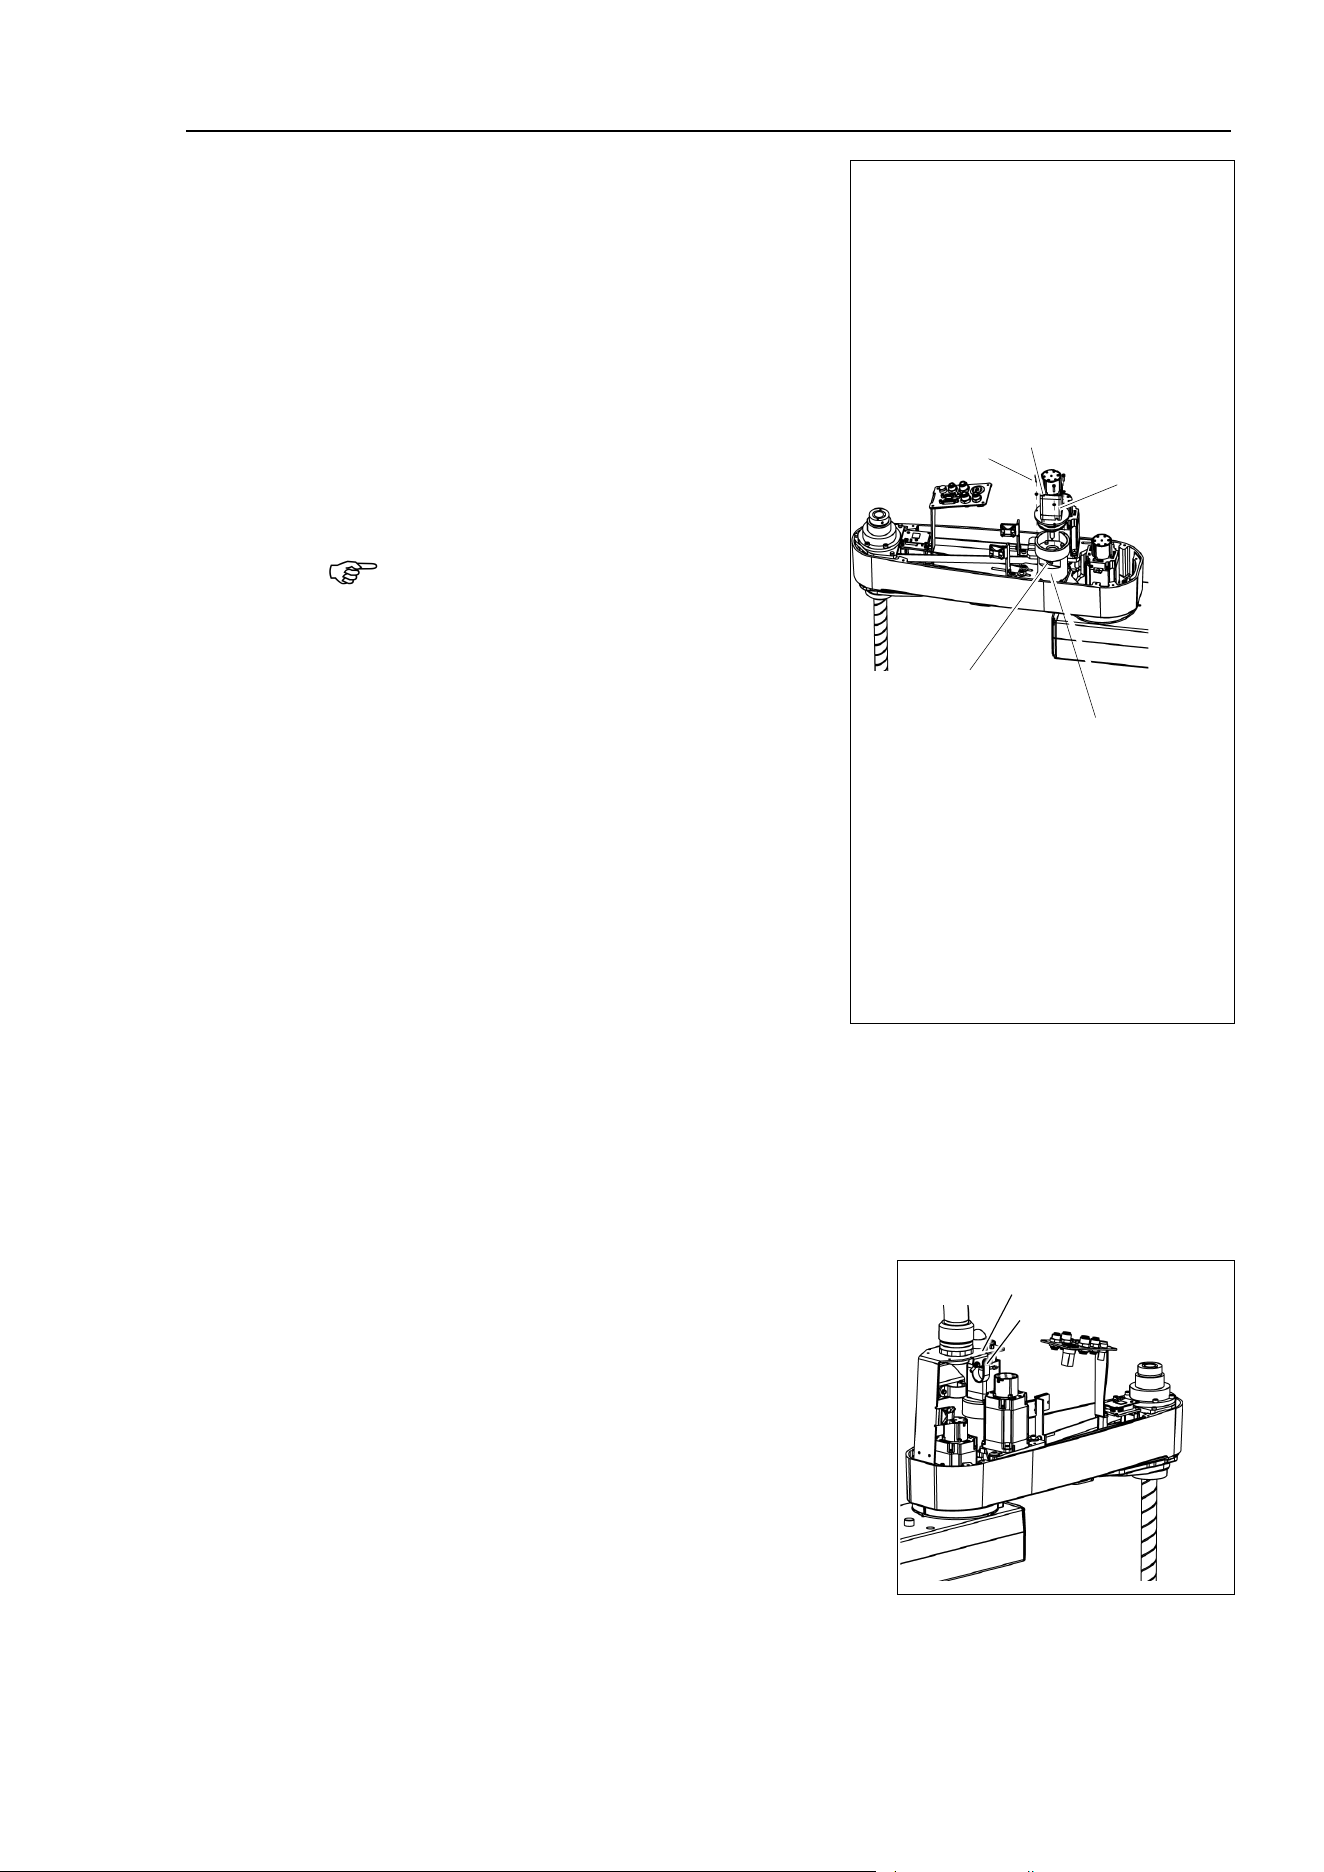
Maintenance 8. Joint #4
LS20-B Rev.4 139
(
4)
Insert the extension shaft to the reduction
gear unit.
Make sure that J
oint #4 motor cable is
sideways when
looking from the front side
of Arm #2.
After
inserting the extension shaft, loosely
secure the motor plate on
the Joint #4 motor
unit with
bolts (M3×12), and loosen the
motor fixing
bolts (M4×70) to secure the
motor loosely.
At this point, make sure that the motor
unit
can be moved by hand, and it will not tilt
when pulled.
Before fixing it to the reduction gear unit,
make sure to rotate Joint #4 reduction unit
two or three times from the output side.
Remove the cover of the hole for fixing the
extension shaft
, and then tighten the bolts to
fix
the extension shaft on the reduction gear
unit.
Joint #4
Motor Unit
3-M3×12
+Plain Washer
Hole for fixing the
extension shaft
Joint #4
Reduction Gear Unit
2-M4×70
(5)
T
ighten the bolts on the loosely secured
motor plate
and the motor to fix Joint #4
motor unit
on the reduction gear unit.
(6)
M
ount the cover of the hole for fixing the extension shaft.
(7)
Mount
the Duct Plate.
For details, refer to Maintenance 3. Covers.
(8)
Connect the following connectors
.
Connectors: BR4, X241, X41
(9)
Install the
clip band removed in the removal step
(5) and bind the cables to fix.
Do not
bend or pull the cables forcibly to allow
unnecessary strain on the cables.
Clip Band
Duct Plate
(10)
Mount
the Arm Top Cover.
For details, refer to Maintenance: 3.1 Arm Top Cover.
NOTE
Maintenance 8. Joint #4
140 L
S20-B Rev.4
(11)
Check if the Joint #
4 moves in a Jog motion by operating from EPSON RC+ menu
-
[Tools]
-[Robot Manager]-[Jog & Teach].
If the Manipulator oscillates with
MOTOR ON and the following errors are detected,
Error 5041: Motor torque output failure in low power state.
Error 4241: Over speed during low power mode was detected.
or when the joint other than Joint #
4
moves, the connector for other joint might be
connected to the Joint #
4 motor. Check the connector connection.
(12)
Execute the calibration of Joint #4.
F
or details, refer to Maintenance: 13. Calibration.
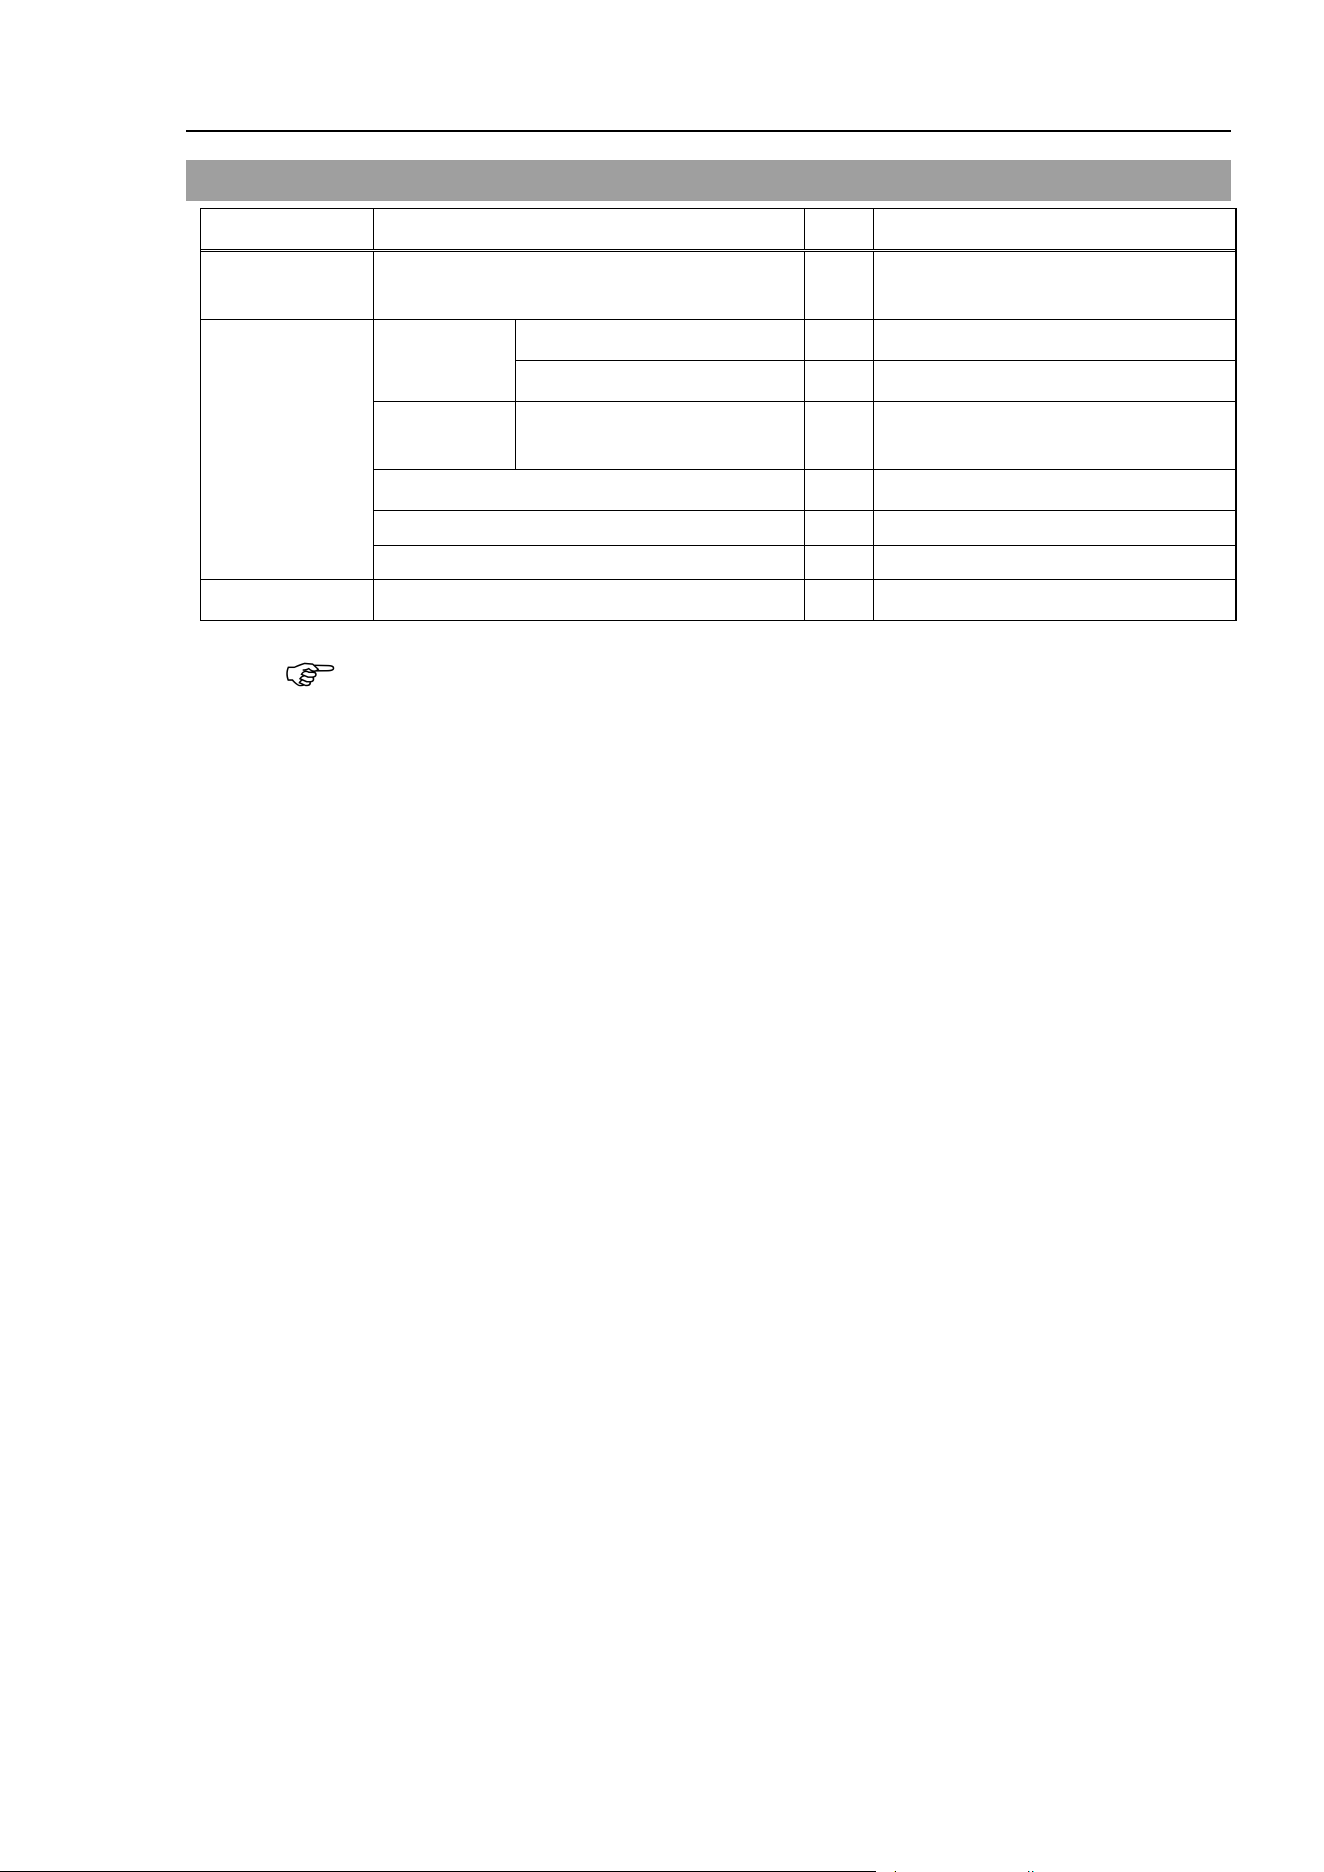
Maintenance 8. Joint #4
LS20-B Rev.4 141
8.4 Replacing the Reduction Gear Unit
Name Qty. Note
Maintenance
part
Reduction Gear Unit 1 1493783
Tools
Hexagonal
wrench
width across flats: 3 mm 1 For M4 screw
width across flats: 4 mm
1
For M5 screw
Spanner
width across flats: 7 mm 1
For M4 hexagon head bolt
and M4 hexagon nut
Cross-point screwdriver (#2)
1
For M4 screws
Torque wrench
1
Sonic tension meter
1
Refer: Unitta U-508
Material Wire tie - For binding cables
The brakes are mounted on the Joints #3 and #4 to prevent the shaft from moving down due
to the weight of the end effector while the power to the Controller is OFF or while the motor
is in OFF status (MOTOR OFF).
Move the shaft down to its lower limit before the replacement procedure following the
removal steps.
NOTE
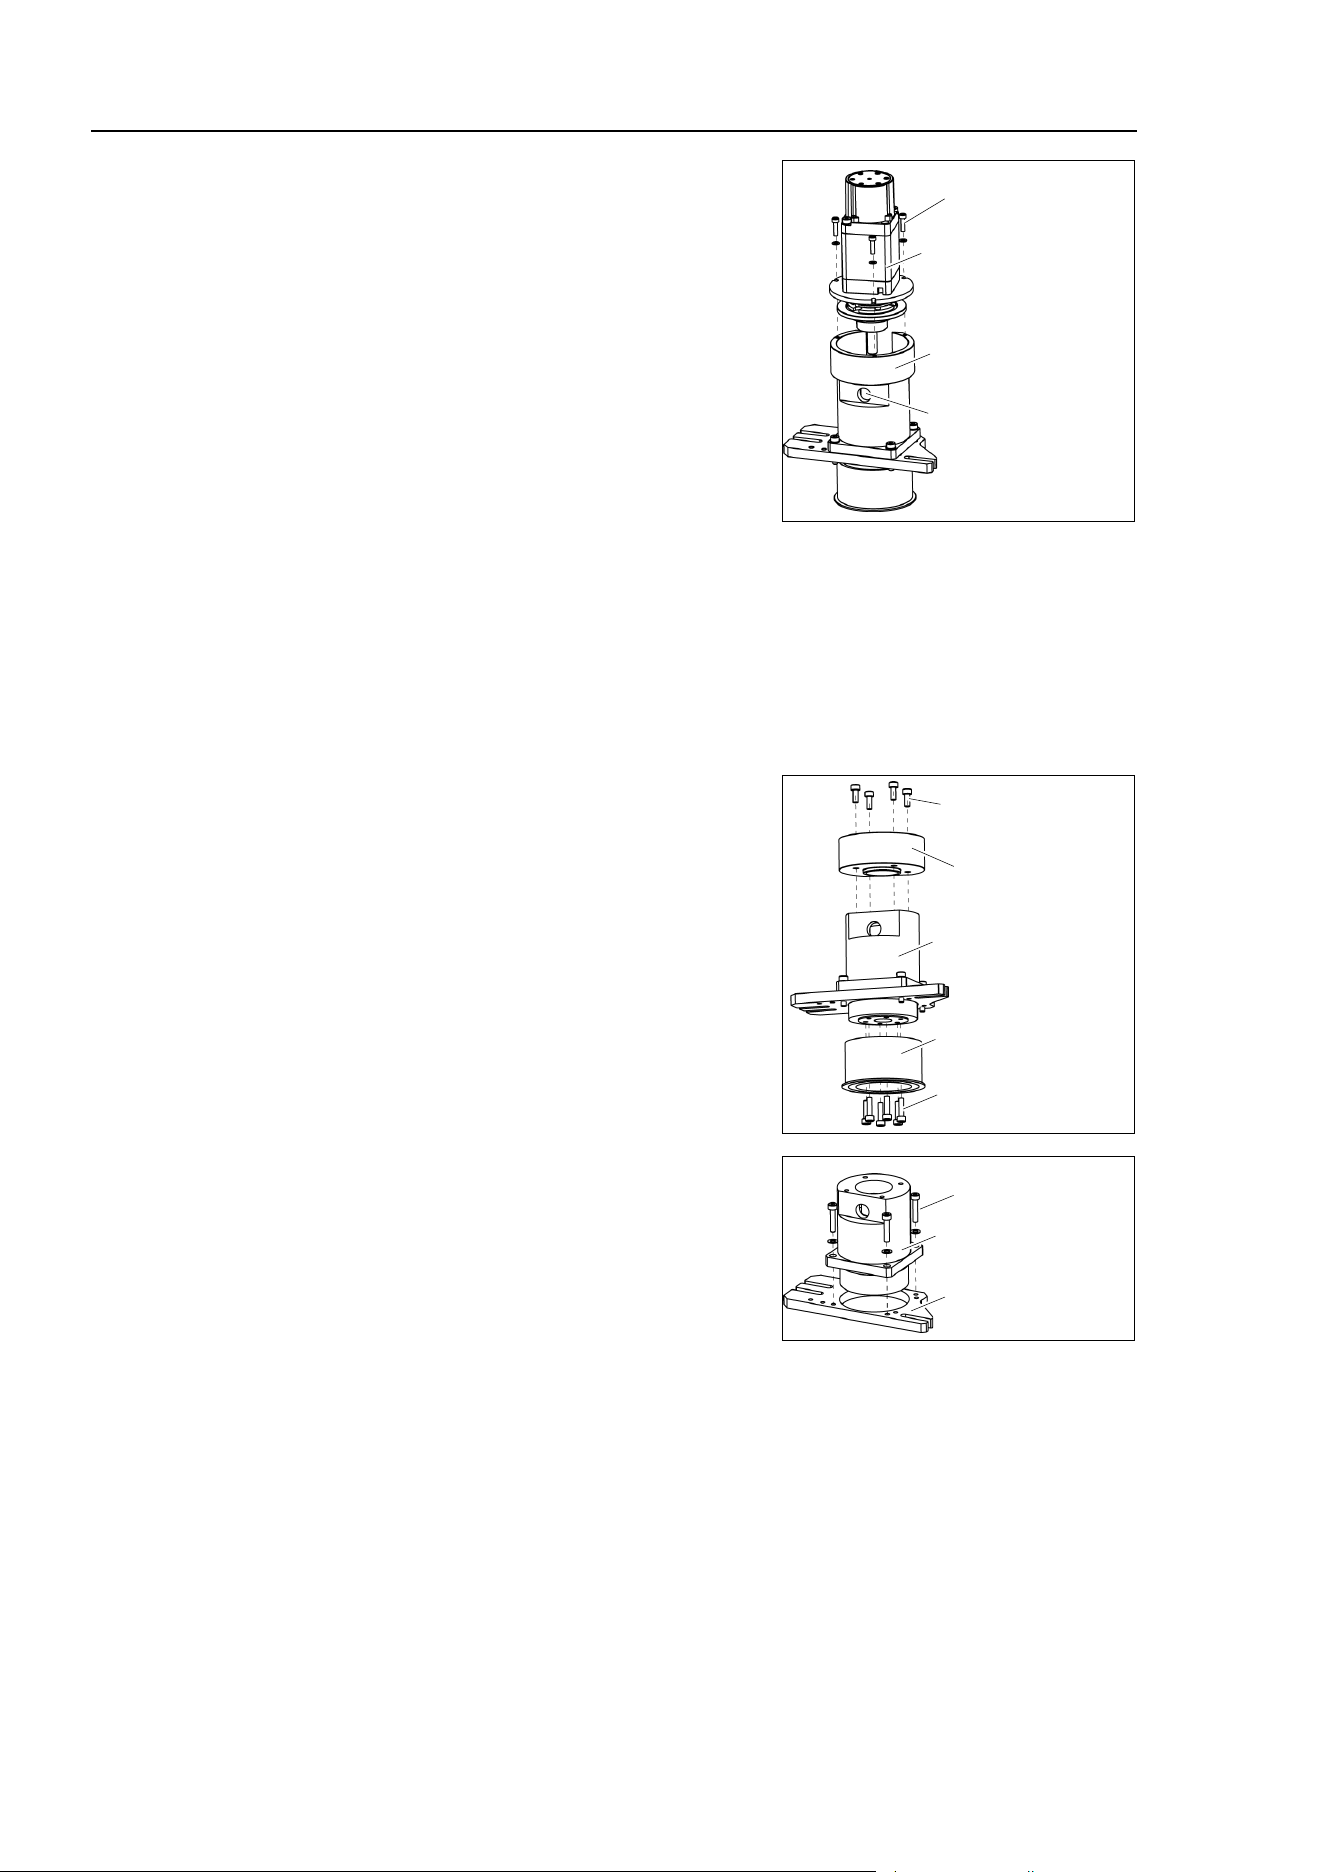
Maintenance 8. Joint #4
142 L
S20-B Rev.4
Joint #4
Reduction Gear
Unit
Removal
(1)
Re
move the Joint #4 motor unit from the Arm
#2.
Fo
r details, refer to the Installation steps in
Maintenance: 8.2 Replacing the Timing Belt.
3-M3×12
+ Plain Washer
Joint #4 Motor
Hole for fixing the
extension shaft
Joint #4
Reduction Gear Unit
(2)
Remove the
screws mounting Joint #4 motor
unit
on the reduction gear unit.
Remove the cover of the hole for fixing the
extension
shaft on the side of the reduction
gear,
and loosen the screws.
If the screw position
does not match, turn the motor slightly and move until the screw
fixing the
extension shaft can be seen.
Remove Joint #4 motor unit from the reduction gear
unit.
Mount the cover of a hole for fixing
the extension shaft on the side of reduction gear
unit.
Pull the moto
r unit upward to remove.
(3)
Remove the
U pulley and U housing.
4-M4×10
U Housing
Joint #4
Reduction Gear Unit
U Pulley
6-M4×15
(4)
Remove the plate.
4-M4×20
Plain Washer
Plate
Joint #4
Reduction Gear Unit
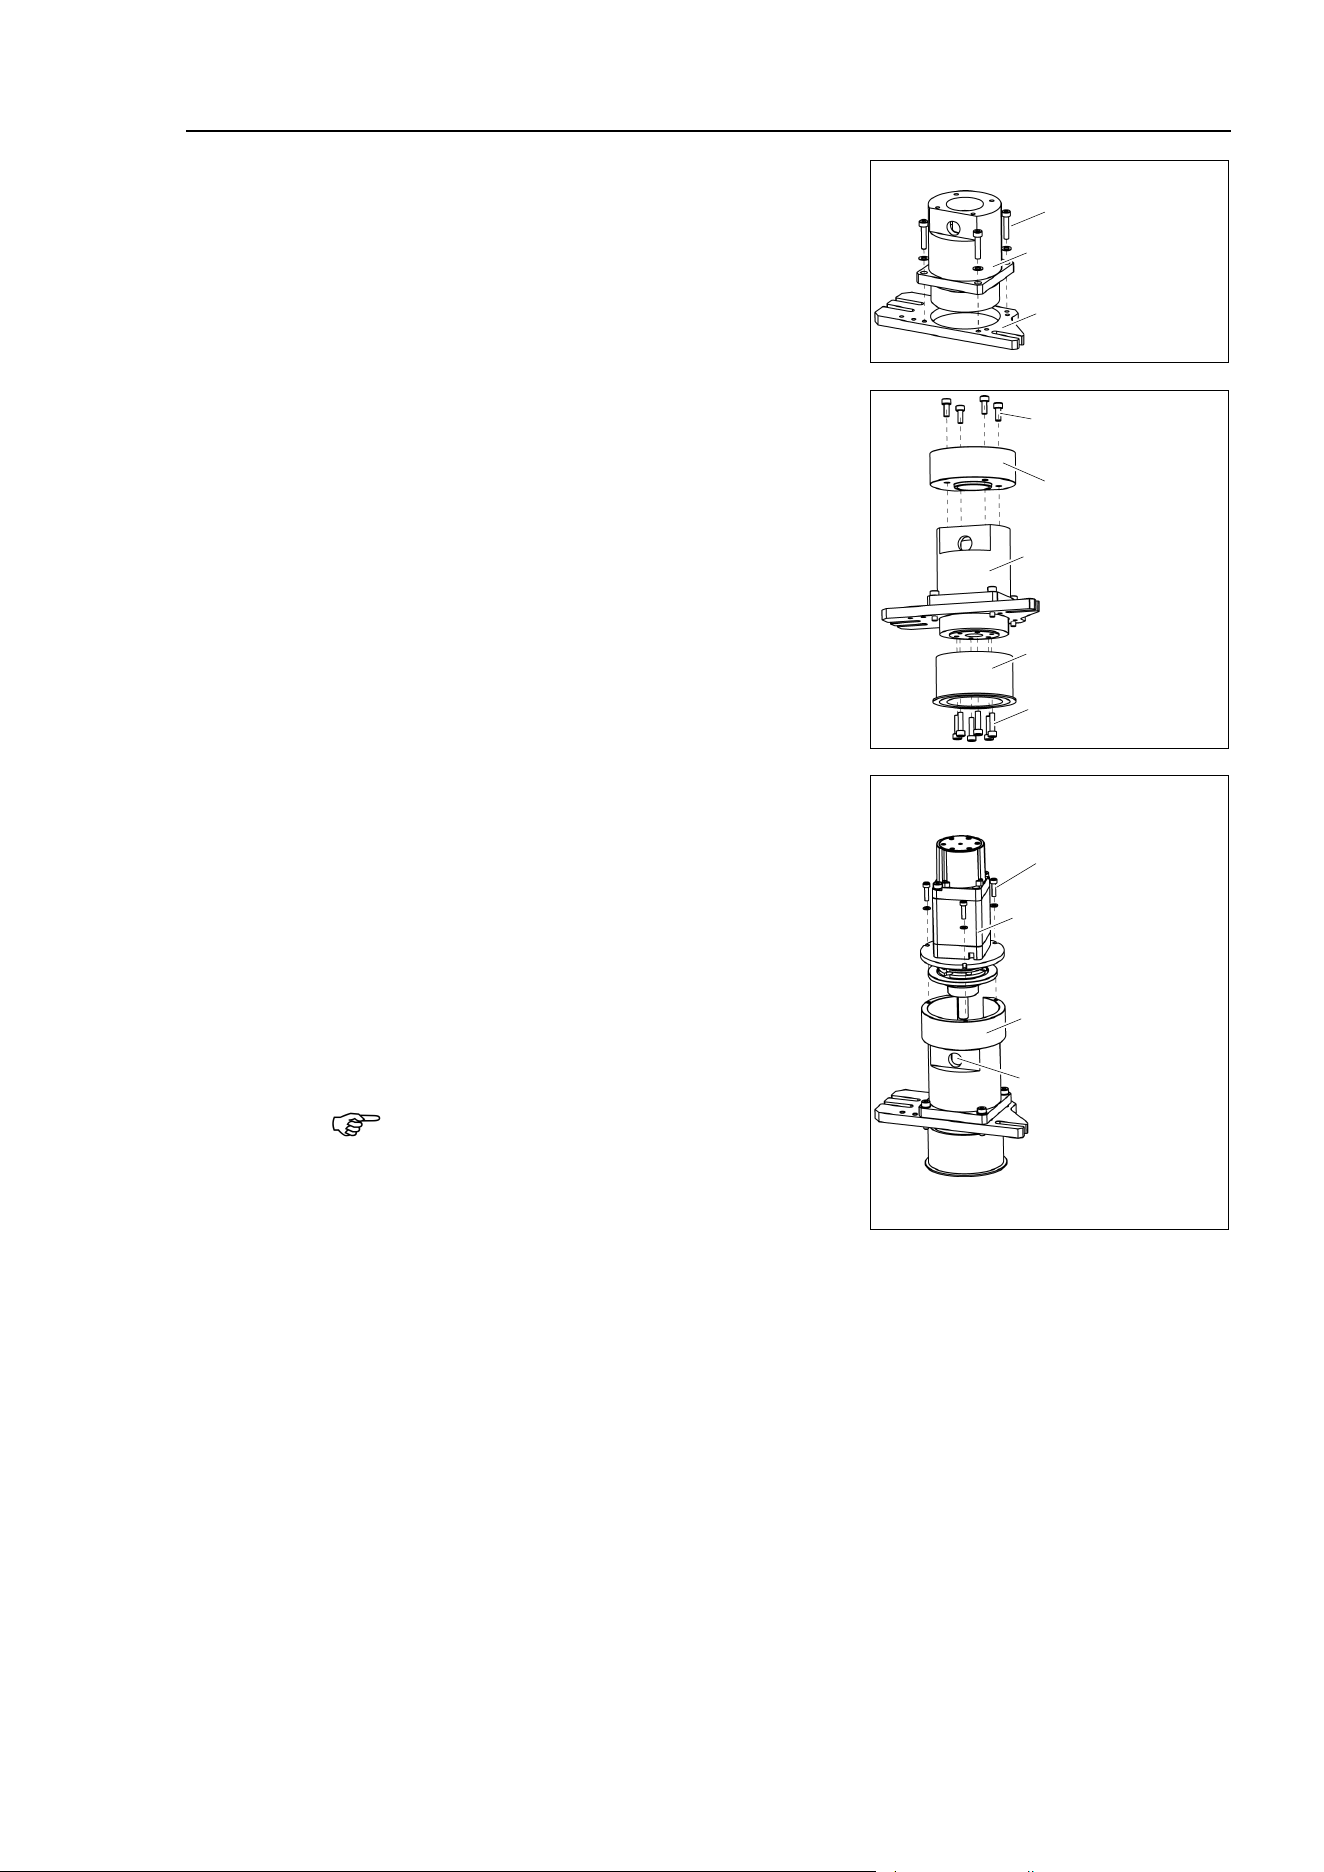
Maintenance 8. Joint #4
L
S20-B Rev.4 143
Joint #4
Reduction Gear
Unit
Installation
(1)
Mount
the plate on a new reduction gear unit.
4-M4×20
Plain Washer
Plate
Joint #4
Reduction Gear Unit
(2)
M
ount the U pulley and the U housing.
4-M4×10
U Housing
Joint #4
Reduction Gear Unit
U Pulley
6-M4×15
(3)
Mount the Joint #4 motor
unit on the reduction
gear
unit.
Insert the extension shaft to the reduction gear
unit.
After
inserting the extension shaft, loosely
secure the motor plate on
the Joint #4 motor
unit with
bolts (M3×12), and loosen the motor
fixing
bolts
(M4×70) to secure the motor
loosely.
At this point, make sure that the motor unit can
be moved by hand, and it will not tilt when
pulled.
3-M3×12
+ Plain Washer
Joint #4 Motor
Hole for fixing the
extension shaft
Joint #4
Reduction Gear Unit
Before fixing it to the reduction gear unit, make sure to rotate Joint #4 reduction unit
two or three times from the output side.
Remove the cover of the hole for fixing the
extension shaft, and then tighten the bolts
to fix
the extension shaft on the reduction gear unit.
After fixing the shaft, mount the cover of the hole for fixing the
extension shaft.
(4)
T
ighten the bolts on the loosely secured motor plate and the motor to fix Joint #4
motor unit
on the reduction gear unit.
(
5)
Mount the Joint #4 motor unit to the Arm #2.
F
or details, refer to Maintenance 8.2 Replacing the Timing Belt.
NOTE
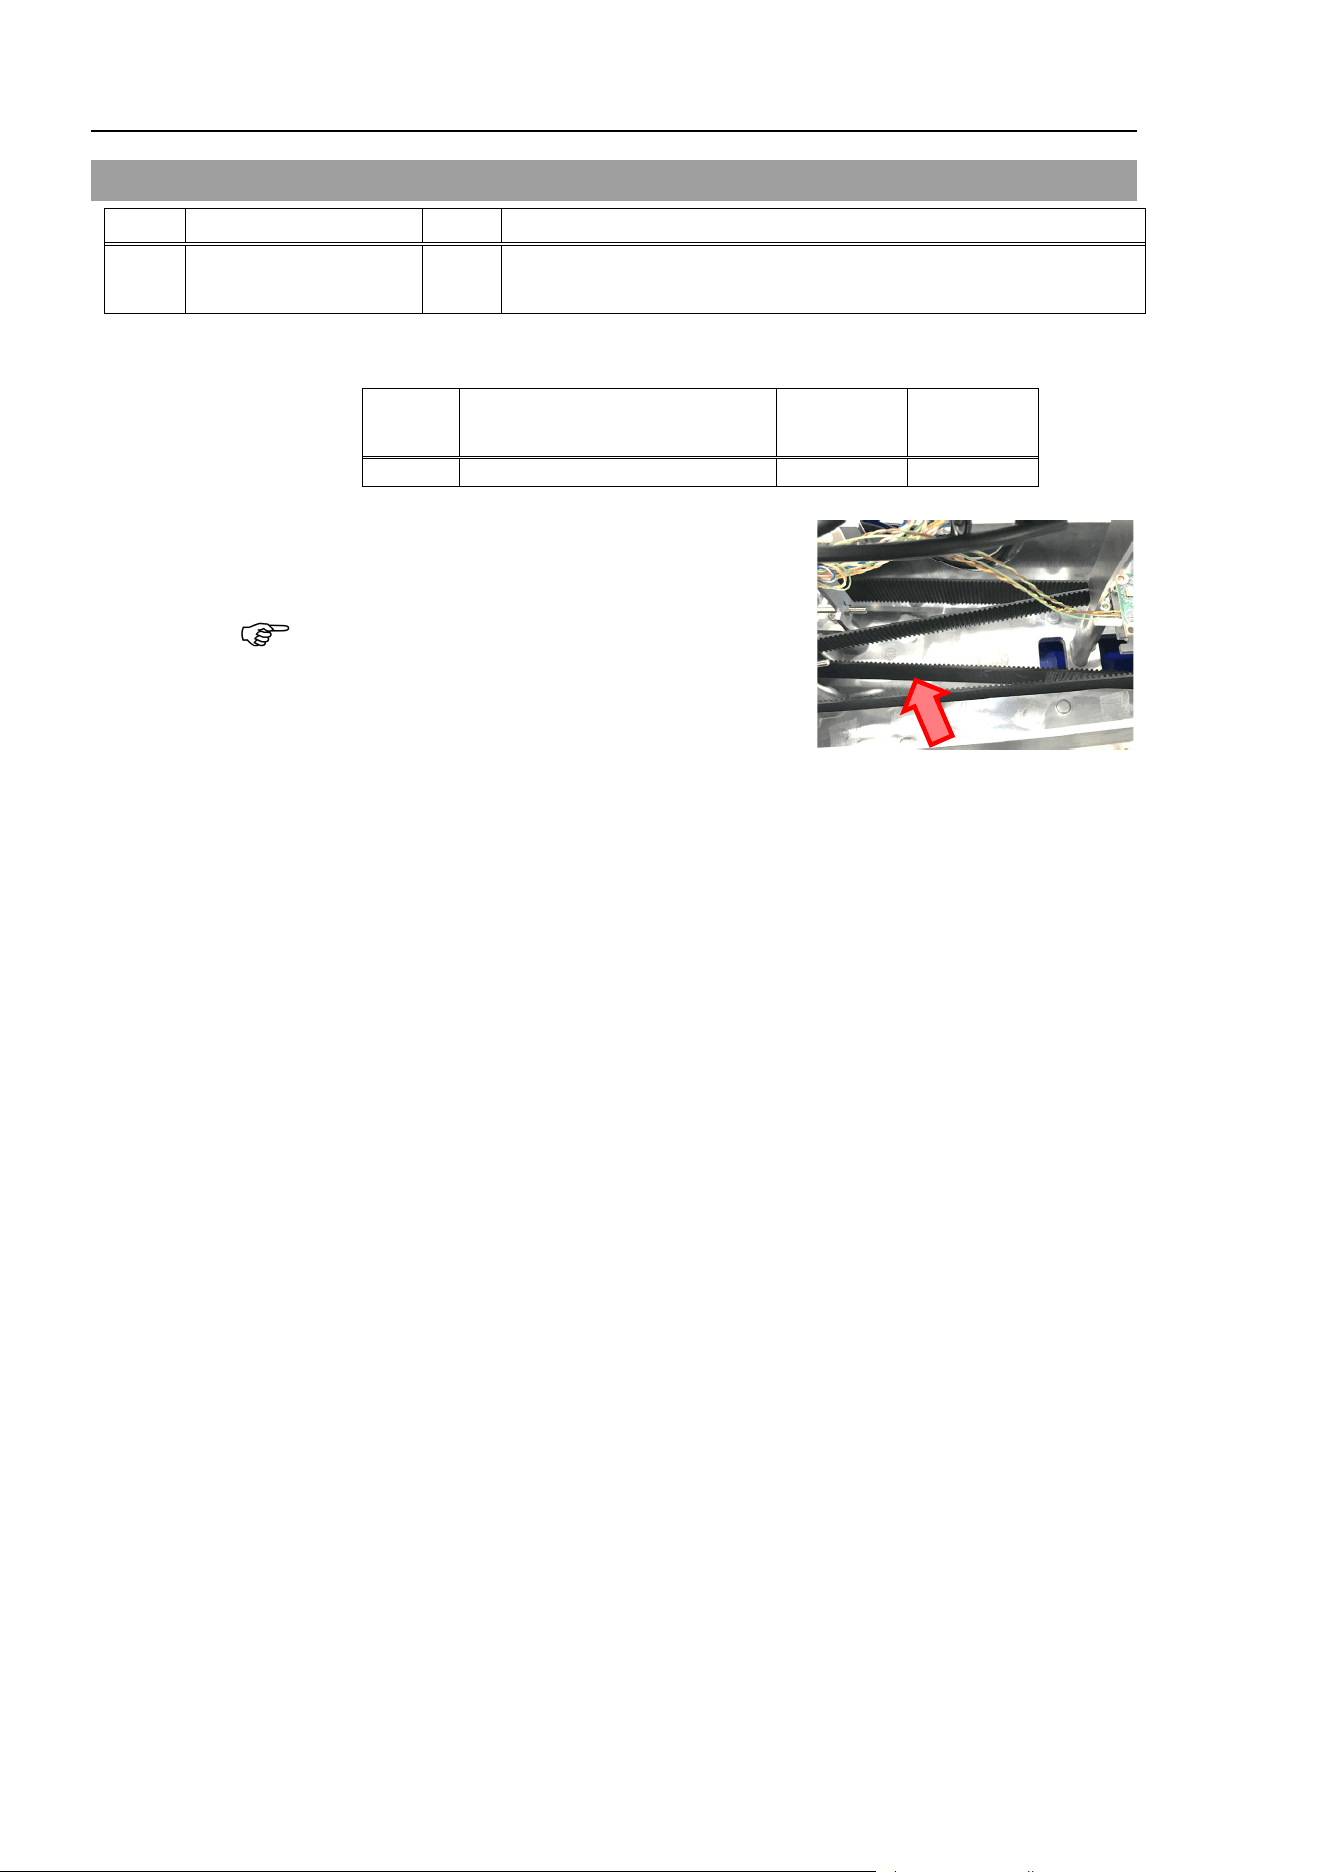
Maintenance 8. Joint #4
144 LS
20-B Rev.4
8.5 Checking the Timing Belt Tension (U Belt)
Name
Qty.
Note
Tool Sonic tension meter 1
For details on
usage and measurement methods of the tension
meter, refer to the instruction manual of the tension meter.
Joint #
4
Belt tension
check
(1)
Enter appropriate setting values to the sonic tension meter.
Belt
Unit mass M
[g/ (1 mm width×1 m length)]
Width W
[mm]
Span S
[mm]
U belt
2.5
30
357
(2)
Strum the belt and measure tension.
Measurement failure may occur if the microphone
touches the belt during measurement.
NOTE
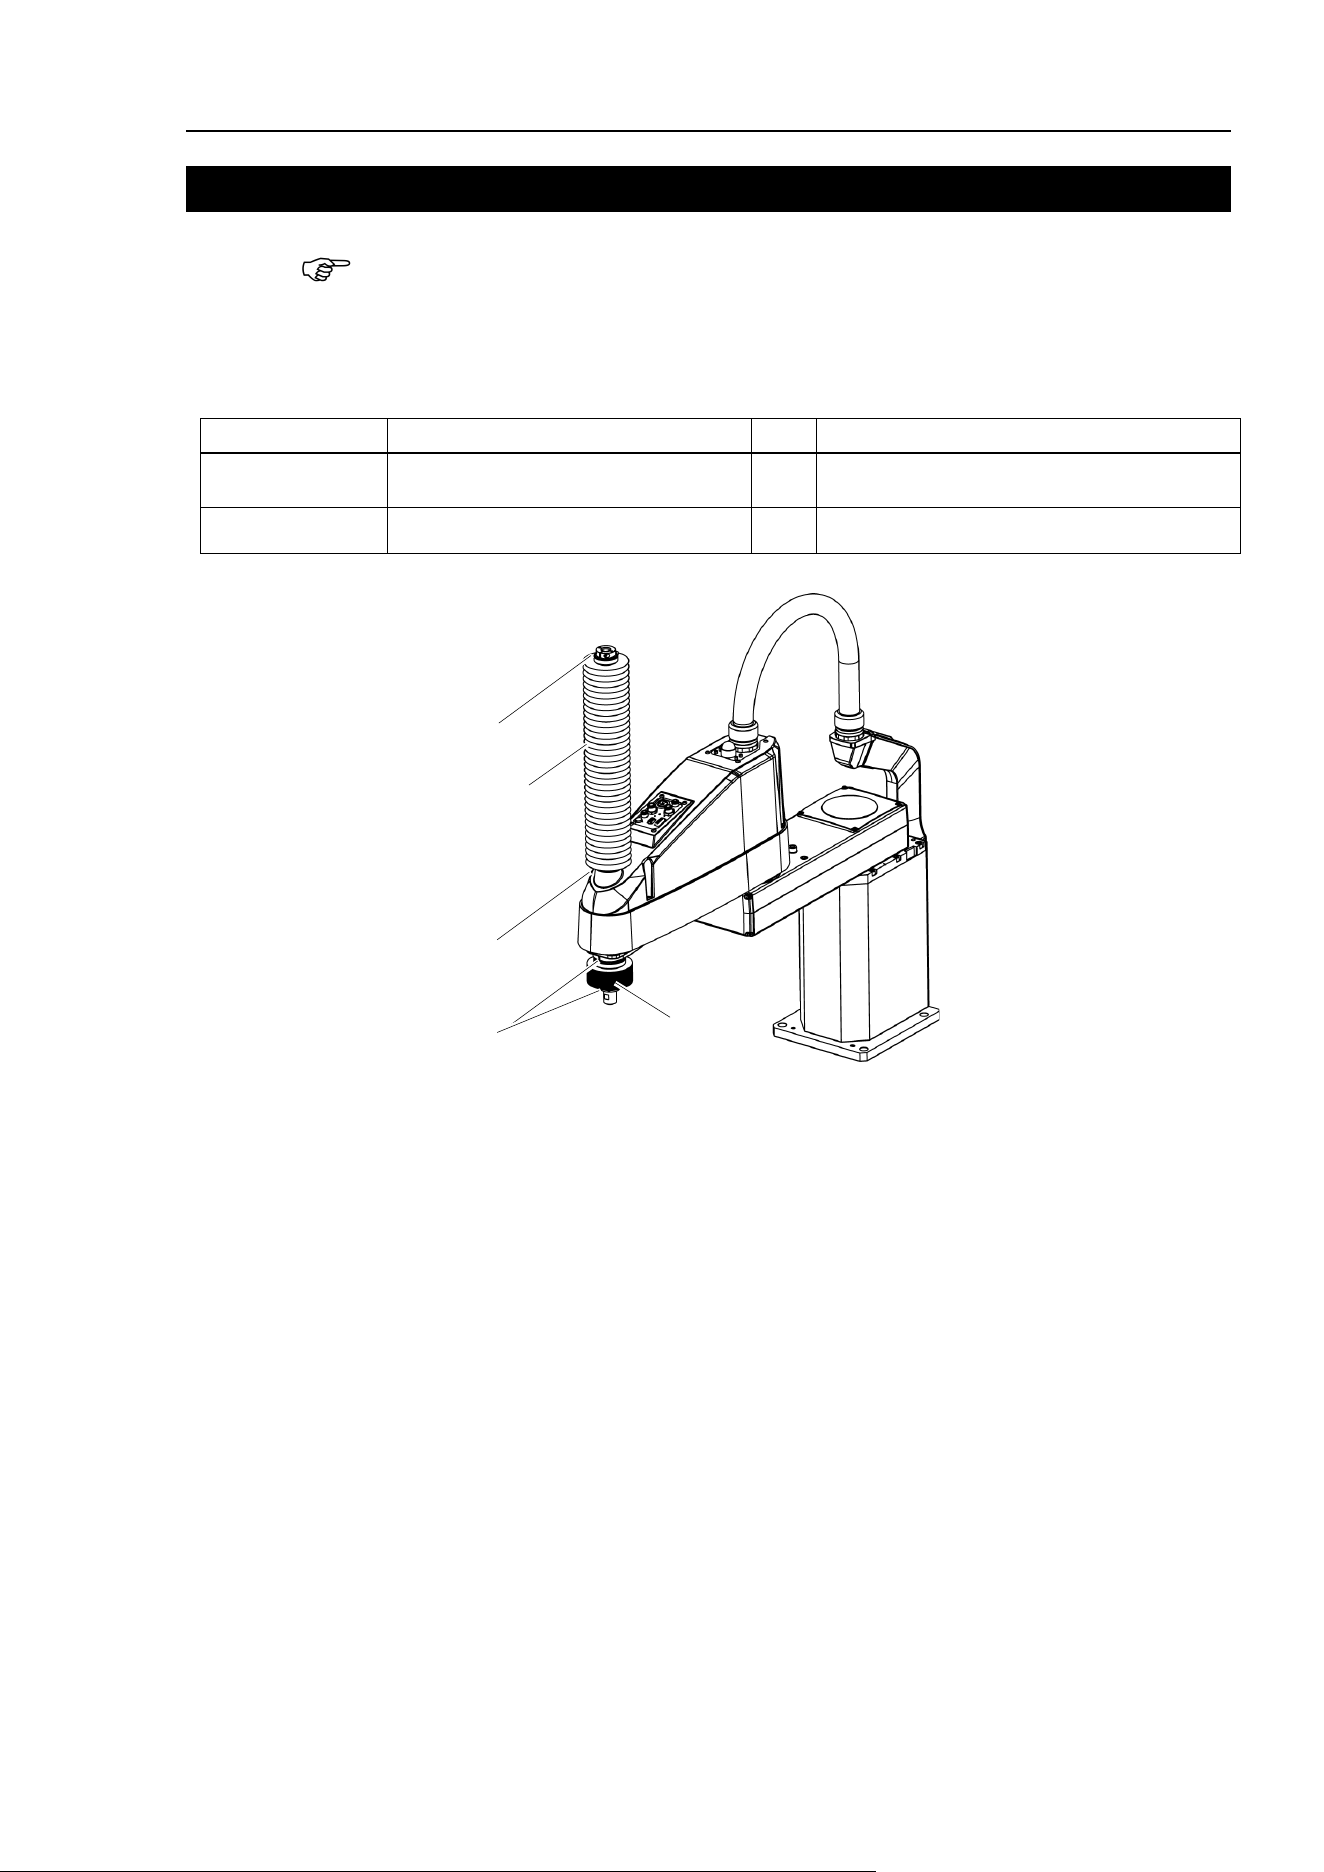
Maintenance 9. Bellows
LS20-B Rev.4 145
9. Bellows
The bellows for LS20-B***C are provided in a unit of two pieces. The shape varies
between the upper and lower bellows.
A large amount of dust is emitted when replacing the bellows. Take the Manipulator to an
outer room such as the room in front of the clean room’s entrance, or take the necessary
countermeasures to prevent dust emission before replacing the bellows.
Name
Qty.
Note
Maintenance
part
Bellows 1
1499591
Tool
Cross-point screwdriver 1 For clamp band removal
Bellows
Bellows
Clamp Band
Clamp Band
Clamp Band
Bellows
Removal
(1)
Remove the
cables and tubes from the end effector.
(2)
Remove the end effector.
(3)
Turn ON the controller. Stop motor excitation. (MOTOR OFF)
(4)
L
oosen the two clamp bands on the bellows.
(5)
Pull
out the bellows and clamp bands from the shaft.
NOTE
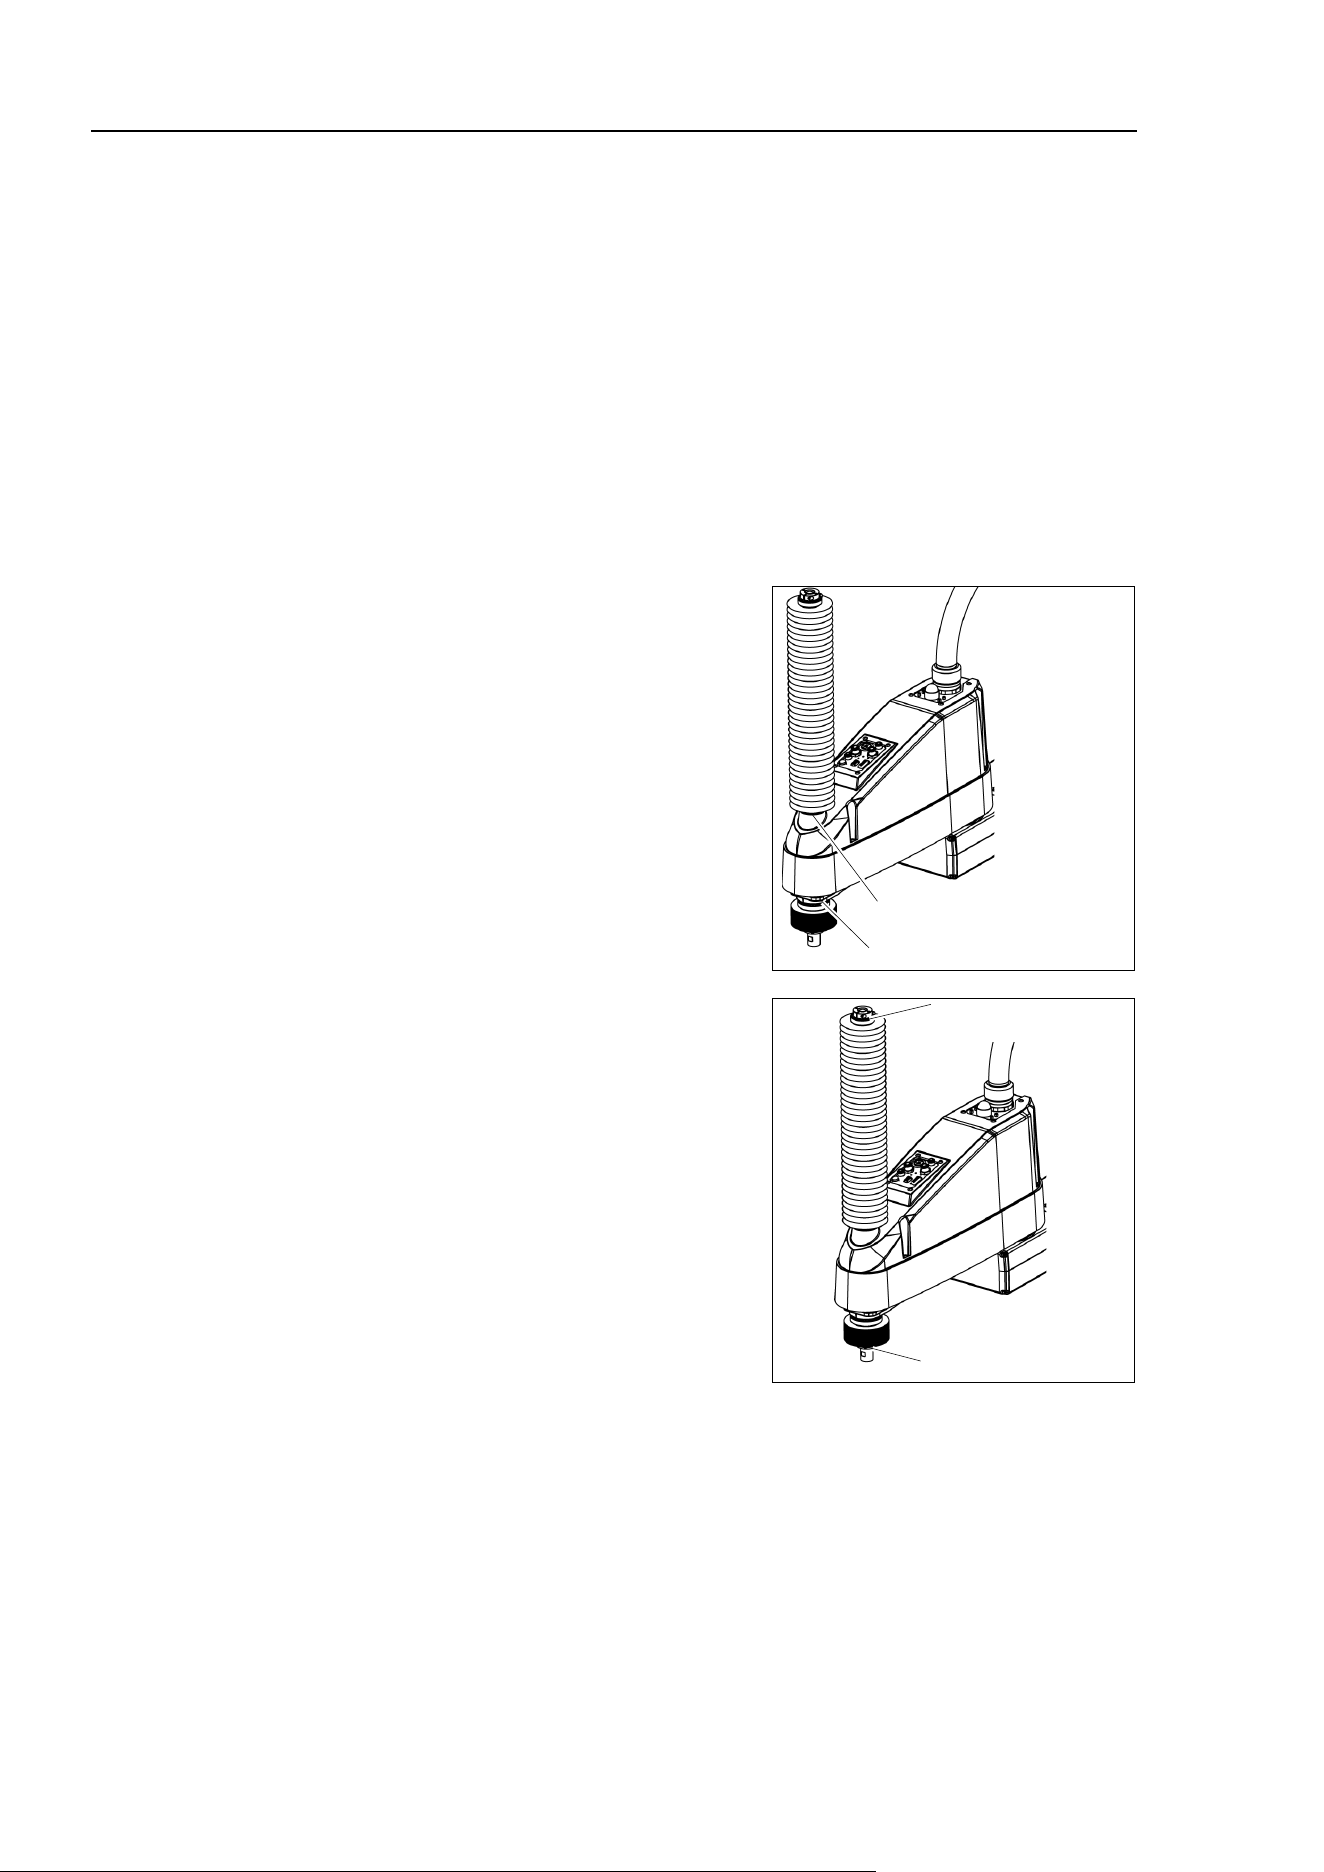
Maintenance 9. Bellows
146 L
S20-B Rev.4
Bellows
Installation
(1)
To attach the upper
bellows, move the shaft to its lower limit.
To attach the lower bellows, move the shaft to its upper
limit.
To move the shaft up/down, press and hold the brake release switch.
Be sure to keep enough space and prevent the
end effector
hitting any peripheral
equipment.
The brake release switch is applied to both Joints #3 and Joint #4.
When the brake
release switch is pressed, the respective brakes of the Joint #3 and
Joint #4 are released simultaneously.
Be careful of the
shaft falling and rotating while the brake release switch is being
pressed
because the shaft may be lowered by the weight of an end effector.
(2)
Pass the shaft through the bellows
from the larger joint.
(3)
Secure the cover side of the bellows.
The bellows has two joints:
The larger joint must be attached to the cover
side.
The smaller joint must be attached to the end
face
side of the shaft.
Attach the mounting part of the bellows
until
the end touches the
cylindrical part of the
cover.
Then, secure them with clamp bands.
Upper bellows cover side
Bottom bellows cover side
(4)
Secure the
shaft edge side of the bellows.
C
over the bearing case (black) on the edge of
the shaft with
the bellows mounting part.
Then, secure them with clamp bands.
Upper bellows
Shaft edge
Bottom bellows
Shaft edge
(5)
When
completed the bellows installation, check that the bellows stretch smoothly
without any excessive force
by moving the shaft up/down by hand and rotating the
Joint #4.
(6)
Turn OFF the
Controller and peripheral equipment.
(7)
A
ttach the end effector.
(8)
C
onnect the cables and tubes to the end effector.
Maintenance 10. Ball Screw Spline Unit
LS20-B Rev.4 147
10. Ball Screw Spline Unit
WARNING
■
Do not connect or disconnect the motor connectors while the power to the robot
system is turned ON. Connecting or disconnecting the motor connectors
with
the power ON is extremely hazardous and may result
in serious bodily injury as
the Manipulator may mo
ve abnormally, and also may result in electric shock
and/or malfunction of the robot system.
■
To shut off power
to the robot system, disconnect the power plug from the power
source. Be sure to connect the AC power cable to a power receptacle.
DO NOT connect it directly to a factory power source.
■
Before performing any replacement procedure, turn OFF the Controller and
related equipment,
and then disconnect the power plug from the power source.
Performing any replacement procedure with the power ON is extremely hazardous
and may result in
electric shock and/or malfunction of the robot system.
After parts have been replaced (motors, reduction gear units, brakes, timing belts, ball screw
spline unit, etc.), the Manipulator cannot operate properly because a mismatch exists
between the origin stored in each motor and its corresponding origin stored in the Controller.
After replacing the parts, it is necessary to match these origins.
The process of aligning the two origins is called “Calibration”.
Refer to Maintenance: 13. Calibration to perform the calibration.
10.1 Greasing the Ball Screw Spline Unit
Name
Qty.
Note
Grease
For Ball Screw Spline Unit
(AFB grease)
Proper
quantity
Tools
Wiping cloth 1
For wiping grease
(Spline shaft)
Cross-point screwdriver 1
For clamp band removal
Only for Cleanroom-model
The brake release switch affects both Joints #3 and #4. When the brake release switch is
pressed in emergency mode, the brake for both Joints #3 and #4 are released simultaneously.
Be careful of the shaft falling and rotating while the brake release switch is pressed because the
shaft may be lowered by the weight of an end effector.
NOTE
NOTE
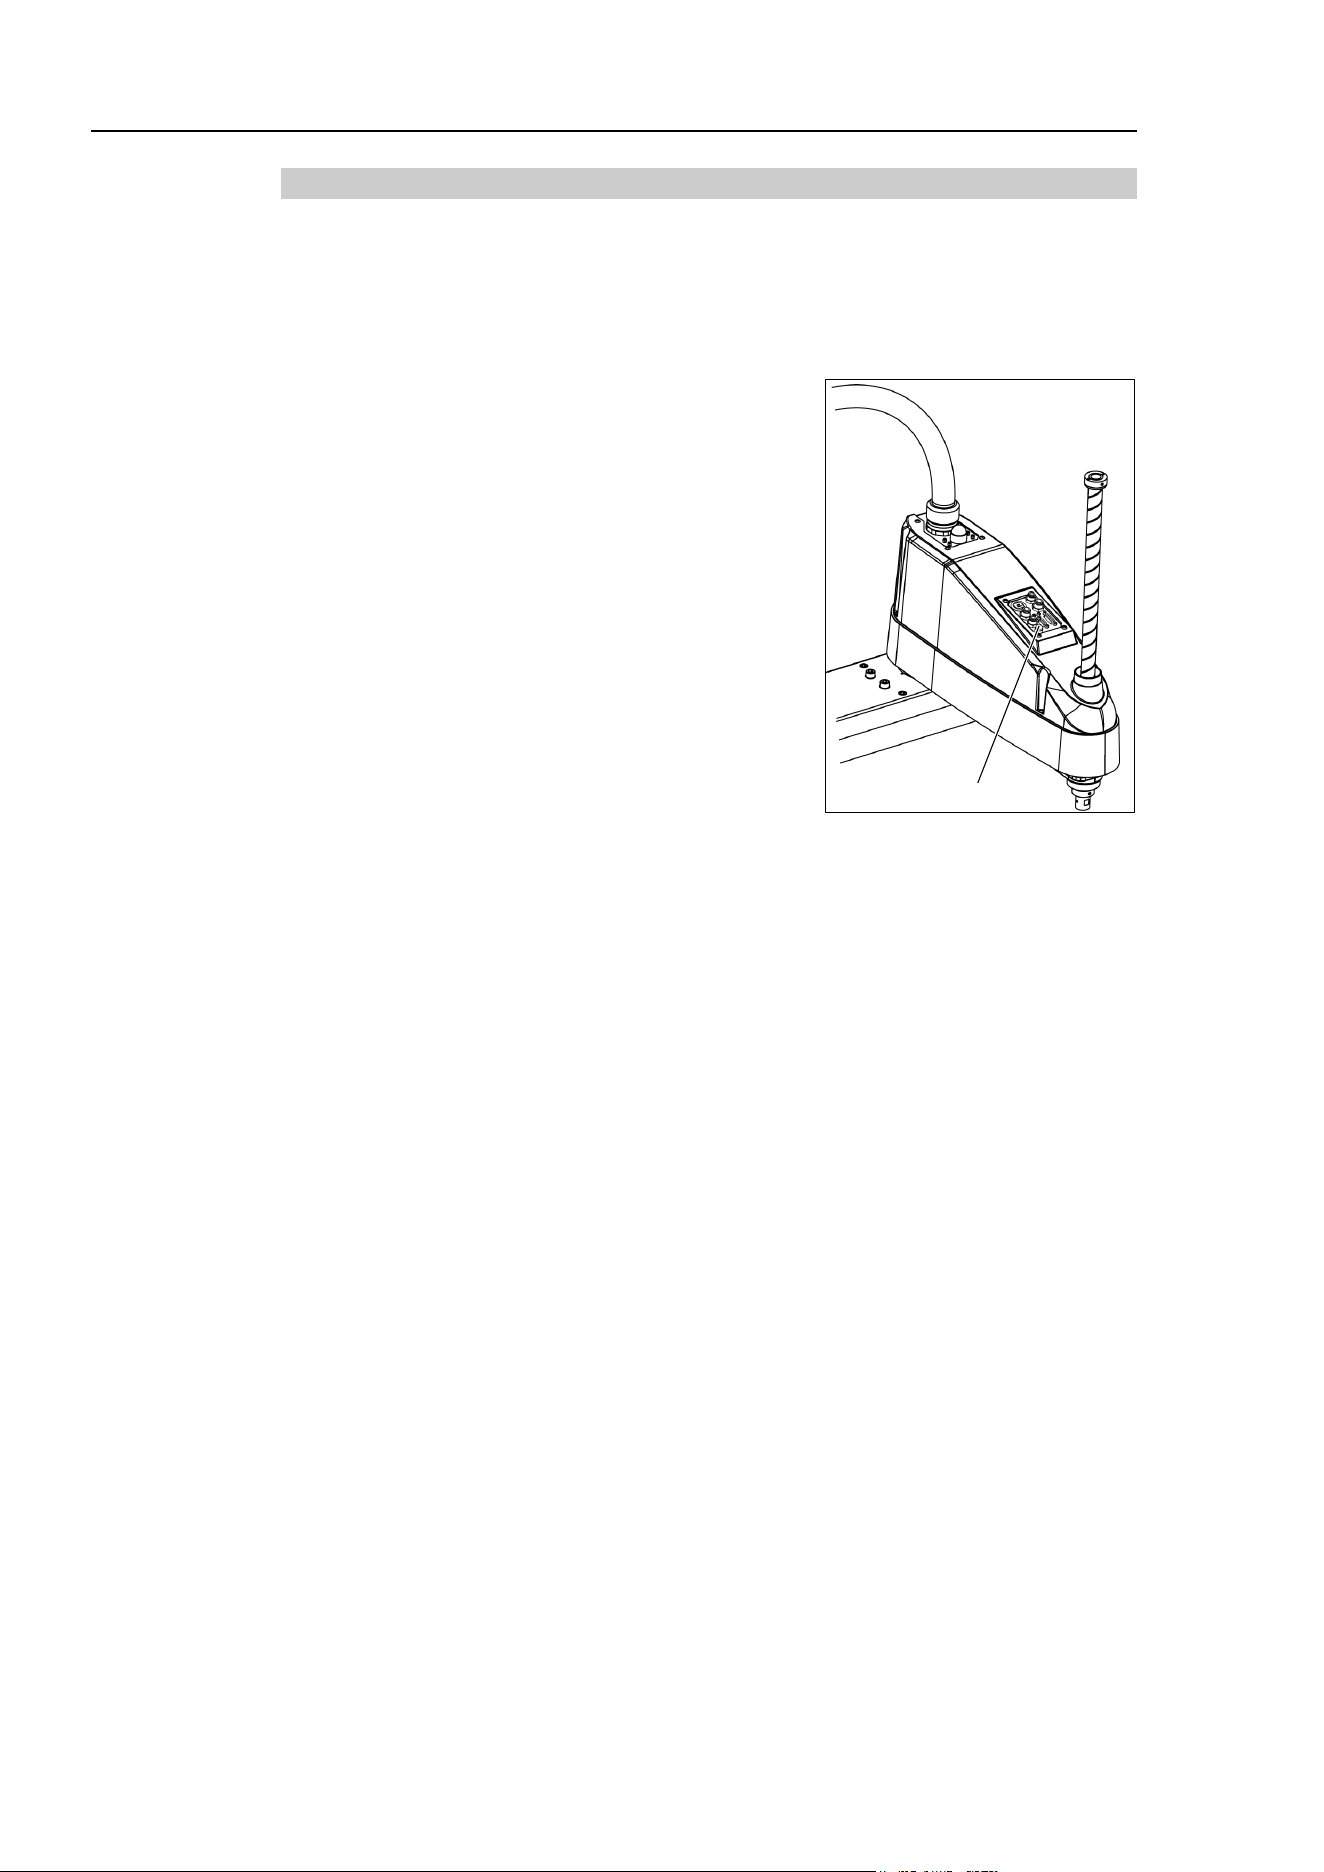
Maintenance 10. Ball Screw Spline Unit
148 L
S20-B Rev.4
10.1.1 Standard-model
Cover the surrounding area such as the end effector and peripheral equipment in case the
grease drips.
(1)
Turn ON the Controller. Stop motor excitation. (MOTOR OFF)
(2)
Move the arm to a position where Joint #3 can be moved in full stroke.
(3)
Move the shaft to its upper limit manually while
pressing the brake release switch.
Brake Release Switch
(4)
Turn OFF the Controller.
(5)
Wipe off the old grease from the upper part of the
shaft, and then apply new grease to it.
When applying the new grease to the upper part of
the shaft, directly fill the grooves on it by hand.
Wipe off excess grease from the shaft.
(6)
Turn ON the Controller.
(7)
Move the shaft to its lower limit by hand while pressing the brake release switch.
(8)
Wipe off the old
grease from the lower part of the shaft, and then apply new grease to
it.
When applying the new grease to the lower part of the shaft, directly fill the grooves
on it by hand. Wipe off excess grease from the shaft.
(9)
Move the shaft up and down several
times while pressing the brake release switch to
smooth out the grease on the shaft. Wipe off excess grease from the shaft.
When wiping off the excess grease from the upper part of shaft, turn OFF the
Controller and remove the Arm Top Cover.
For details, refer to Maintenance: 3.1 Arm Top Cover.
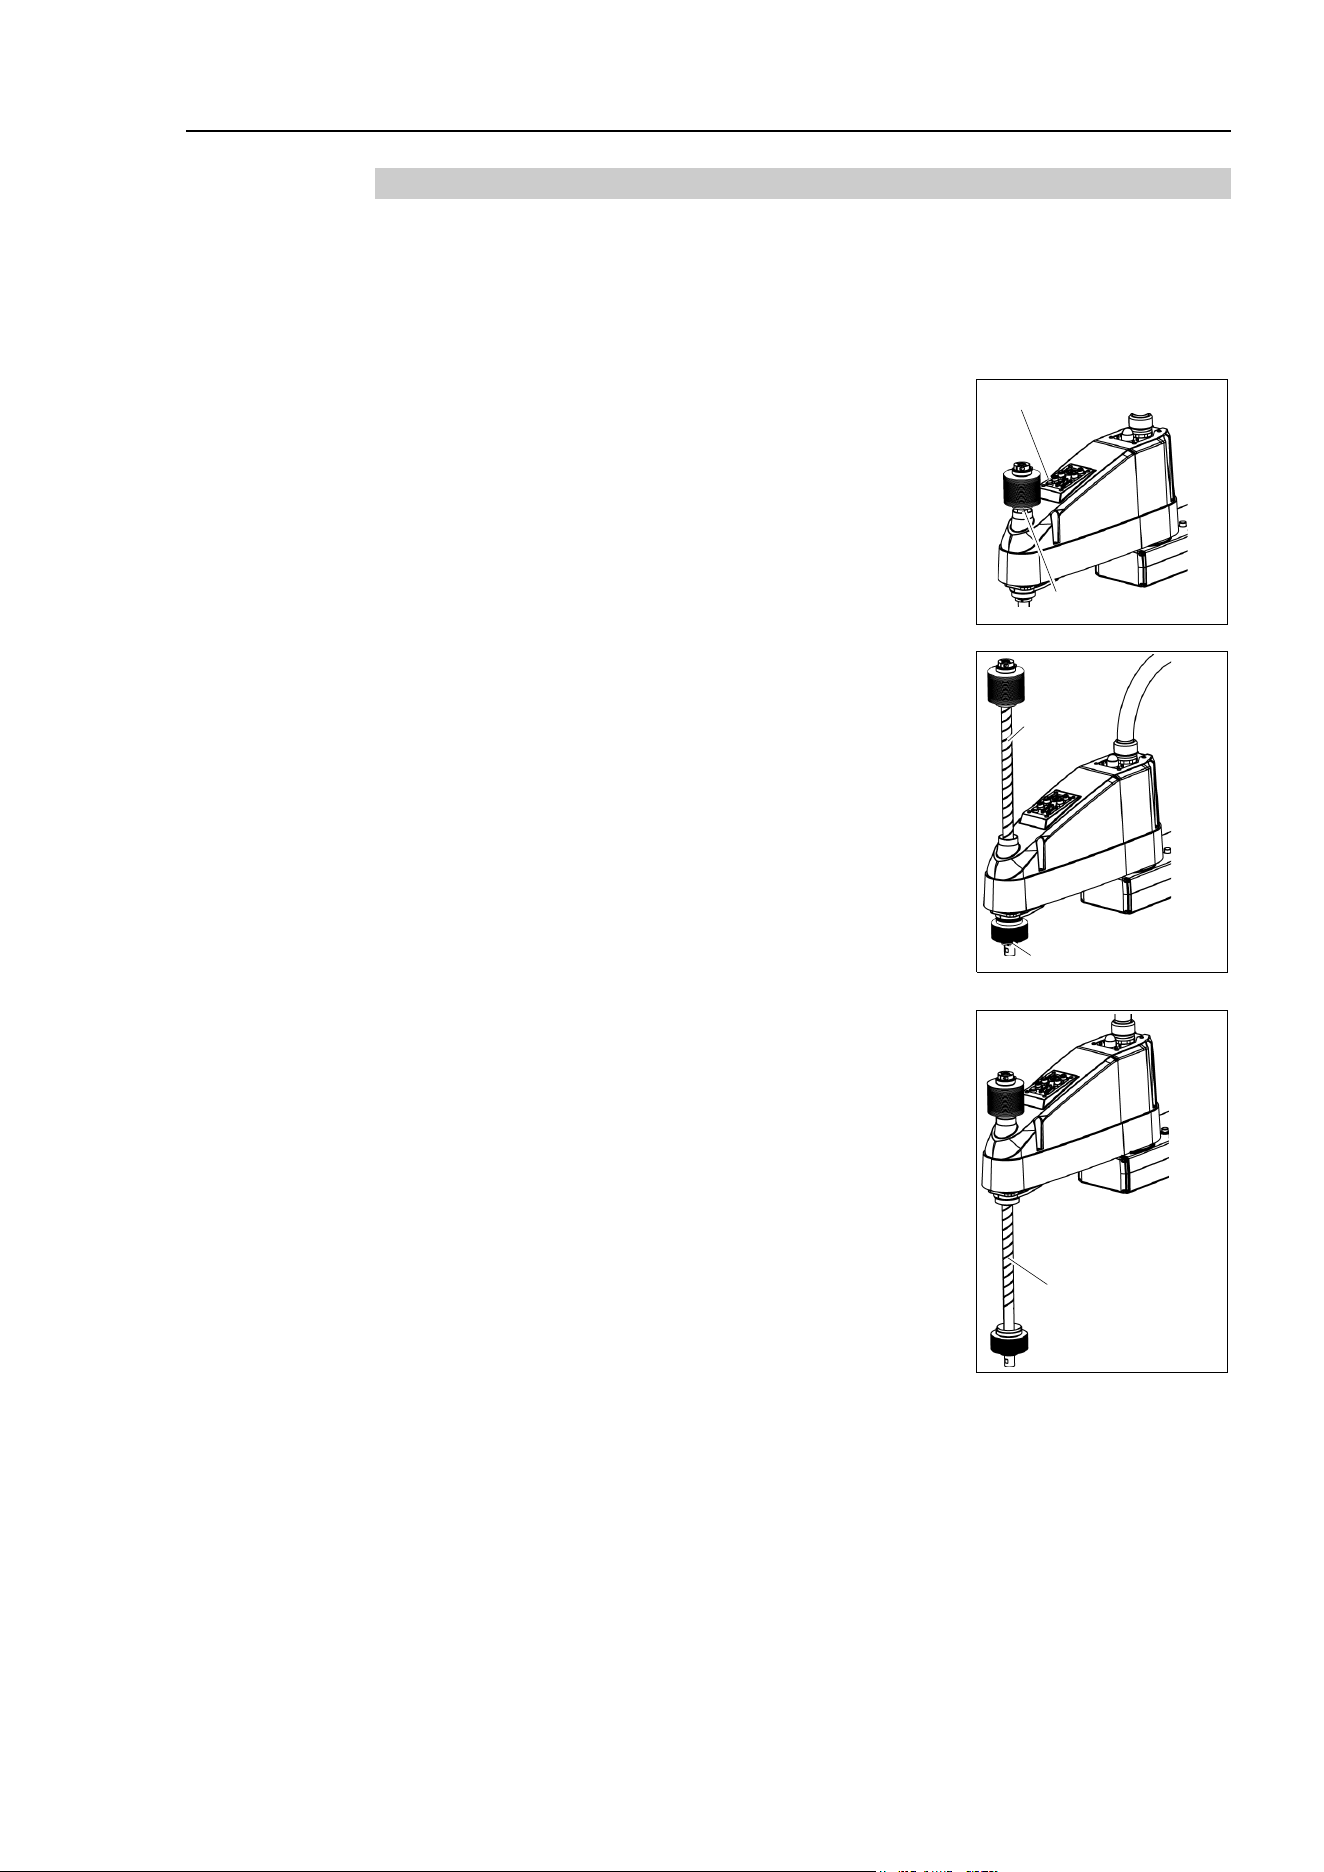
Maintenance 10. Ball Screw Spline Unit
LS20-B Rev.4 149
10.1.2 Cleanroom-model
Cover the surrounding area such as the end effector and peripheral equipment in case the
grease drips.
Upper Part
of the Shaft
(1)
Turn ON the
Controller. Stop motor excitation. (MOTOR OFF)
(2)
Move the arm to a position where Joint #3 can be moved in full stroke.
(3)
Move the shaft to
the lower limit manually while pressing
the brake release switch.
Brake Release Switch
(4) Clamp Band
(4)
Loosen the clamp band
under the bellows, and then lift
the bellows.
(5)
Move the shaft to
the upper limit manually while pressing
the brake release switch.
(6)
Wipe off the old grease from the upper part of the shaft,
and then apply new grease.
Directly fill the
grooves on the shaft inside the bellows
with grease by hand.
Wipe off excess grease
from the shaft.
(6) Shaft
(7) Clamp Band
Lower Part
of the Shaft
(7)
Loosen the clamp band on the bellows, and then move
the bellows downward.
(8)
Move the shaft to
the lower limit manually while pressing
the brake release switch.
(9)
Wipe off the old grease from the lower part of the shaft,
and then apply new grease
.
Directly fill the grooves on the shaft inside the bellows
with grease by
hand.
Wipe off excess grease
from the shaft.
(9) Shaft
(10)
Move the
shaft up and down several times while pressing
the brake release switch to
smooth out the grease on the
shaft.
Wipe off excess grease from the shaft.
(11)
Secure the bellows.
To attach the upper
bellows, move the shaft to its lower limit.
To attach the lower bellows, move the shaft to its upper limit.
To move the shaft up/down, press and hold the brake release switch.
Attach the mounting part of the bellows
until it touches the cylindrical
part of the cover.
Then, secure them with clamp bands.
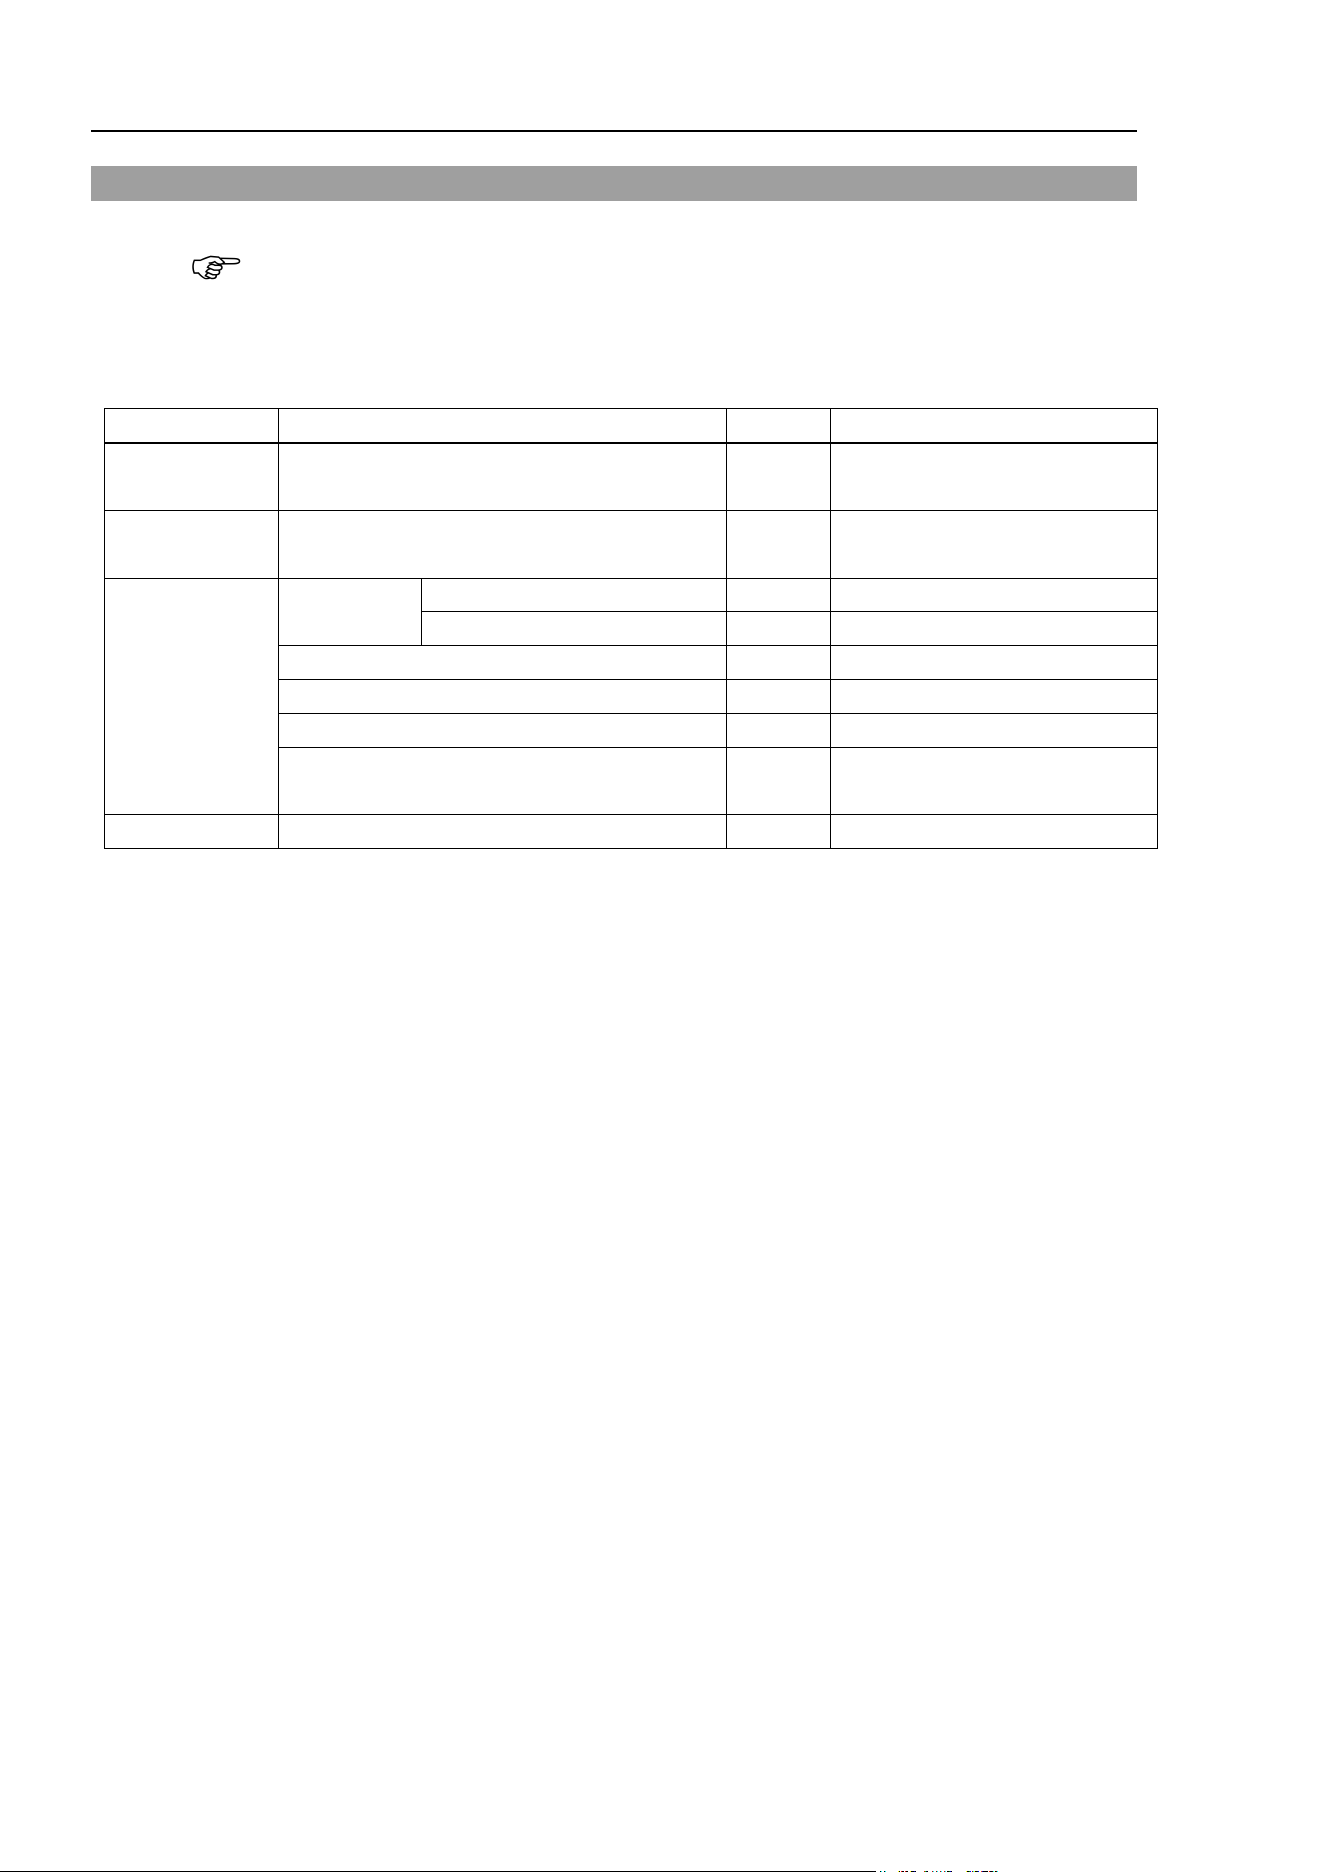
Maintenance 10. Ball Screw Spline Unit
150 L
S20-B Rev.4
10.2 Replacing the Ball Screw Spline Unit
A brake is mounted on the motor of Joints #3 and #4 to prevent the shaft from moving down
and rotating due to the weight of the end effector while the power to the Controller is OFF
or while the motor is in OFF status (MOTOR OFF).
Move the shaft down to its lower limit before the replacement procedure following the
removal steps.
Name
Qty.
Note
Maintenance
part
Ball Screw Spline Unit 1
1646487: For LS20-B*04S
1646488: For LS20-B*04C
Grease
For Ball Screw Spline Unit
(AFB grease)
Proper
quantity
Tools
Hexagonal
wrench
width across flats: 3 mm
1
For M4 screw
width across flats: 4 mm
1
For M5 screw
Torque wrench
1
Nippers
1
For cutting wire tie
Cross-point screwdriver (#2)
1
Wiping cloth 1
For wiping grease
(Spline shaft)
Material
Wire tie
-
NOTE
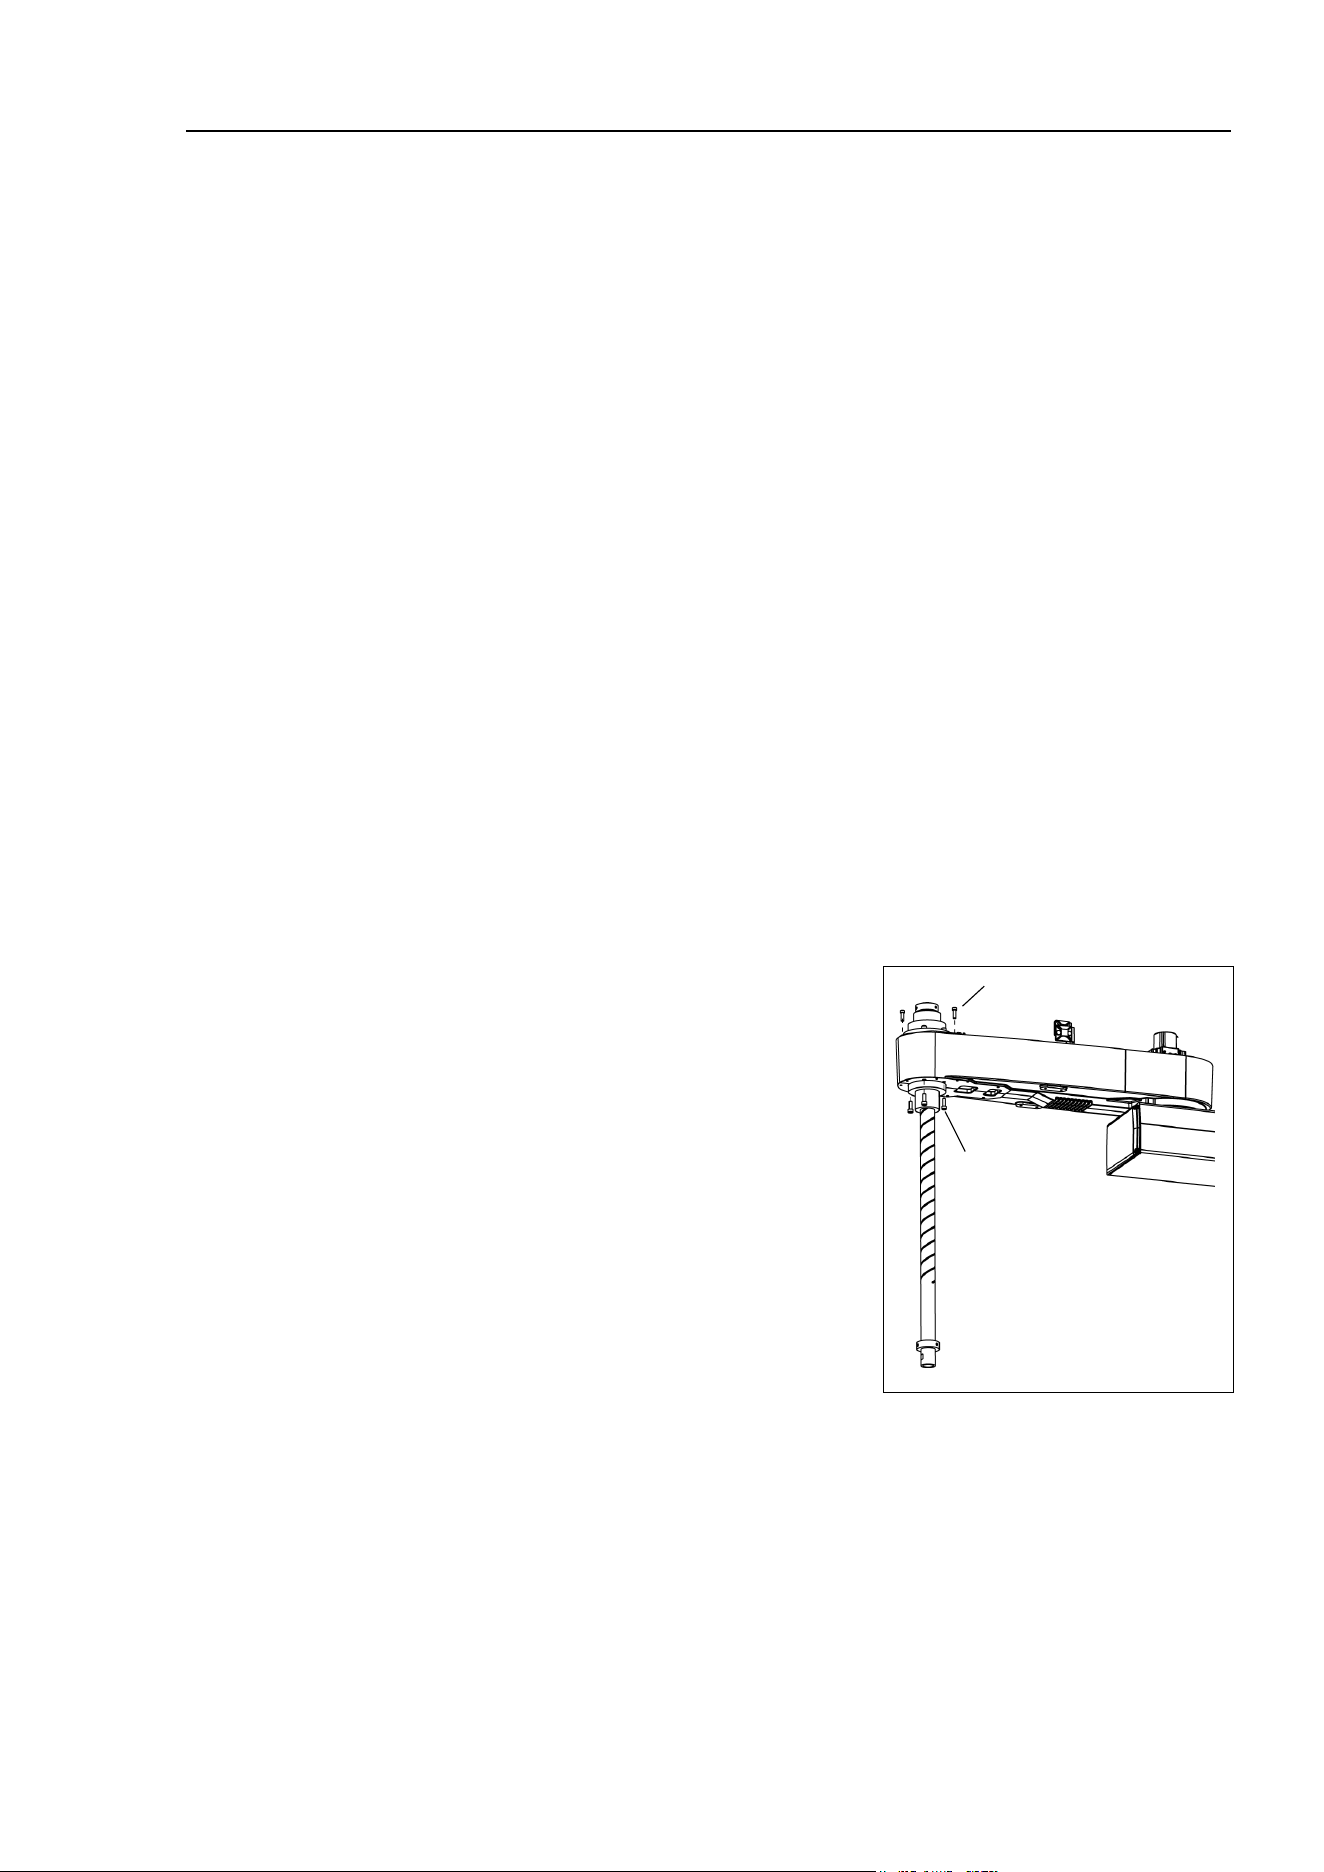
Maintenance 10. Ball Screw Spline Unit
LS20-B Rev.4 151
Ball
Screw
S
pline Unit
Removal
(1)
Turn ON the Controller.
(2)
Push down the shaft to its lower limit while pre
ssing the brake release switch.
Be sure to keep enough space and prevent
the end effector hitting any
peripheral
equipment.
The brake release switch is applied to both Joints #3 and Joint #4.
When the brake release switch is pressed, the respective brakes of the Joint #3 and Joint
#4 are
released simultaneously.
Be careful of the
shaft falling and rotating while the brake release switch is
being
pressed
because the shaft may be lowered by the weight of an end effector.
(3)
Turn OFF the Controller.
(4)
Detach the wires/tubes from
the end effector, and remove the end effector.
(5)
This s
tep is only for Cleanroom-model.
Remove the bellows. For details, refer to Maintenance: 9. Bellows.
(6)
Remove the
Arm Top Cover and Arm Bottom Cover.
For details, refer to Maintenance: 3. Covers.
(7)
Remove the following
parts:
Joint #3 motor unit Joint #4 motor unit
For details, refer to the following manuals:
Maintenance 7.1 Replacing Joint #3 Motor
Maintenance 8.1 Replacing Joint #4 Motor
(8)
Remove three screws mounting the spline
plate.
4-M5×15
3-M4×15
(9)
Remove four screws mounting the spline nut.
(10
)
Pull out the following toward the Arm #2 upper side.
Ball screw spline unit Z belt U belt
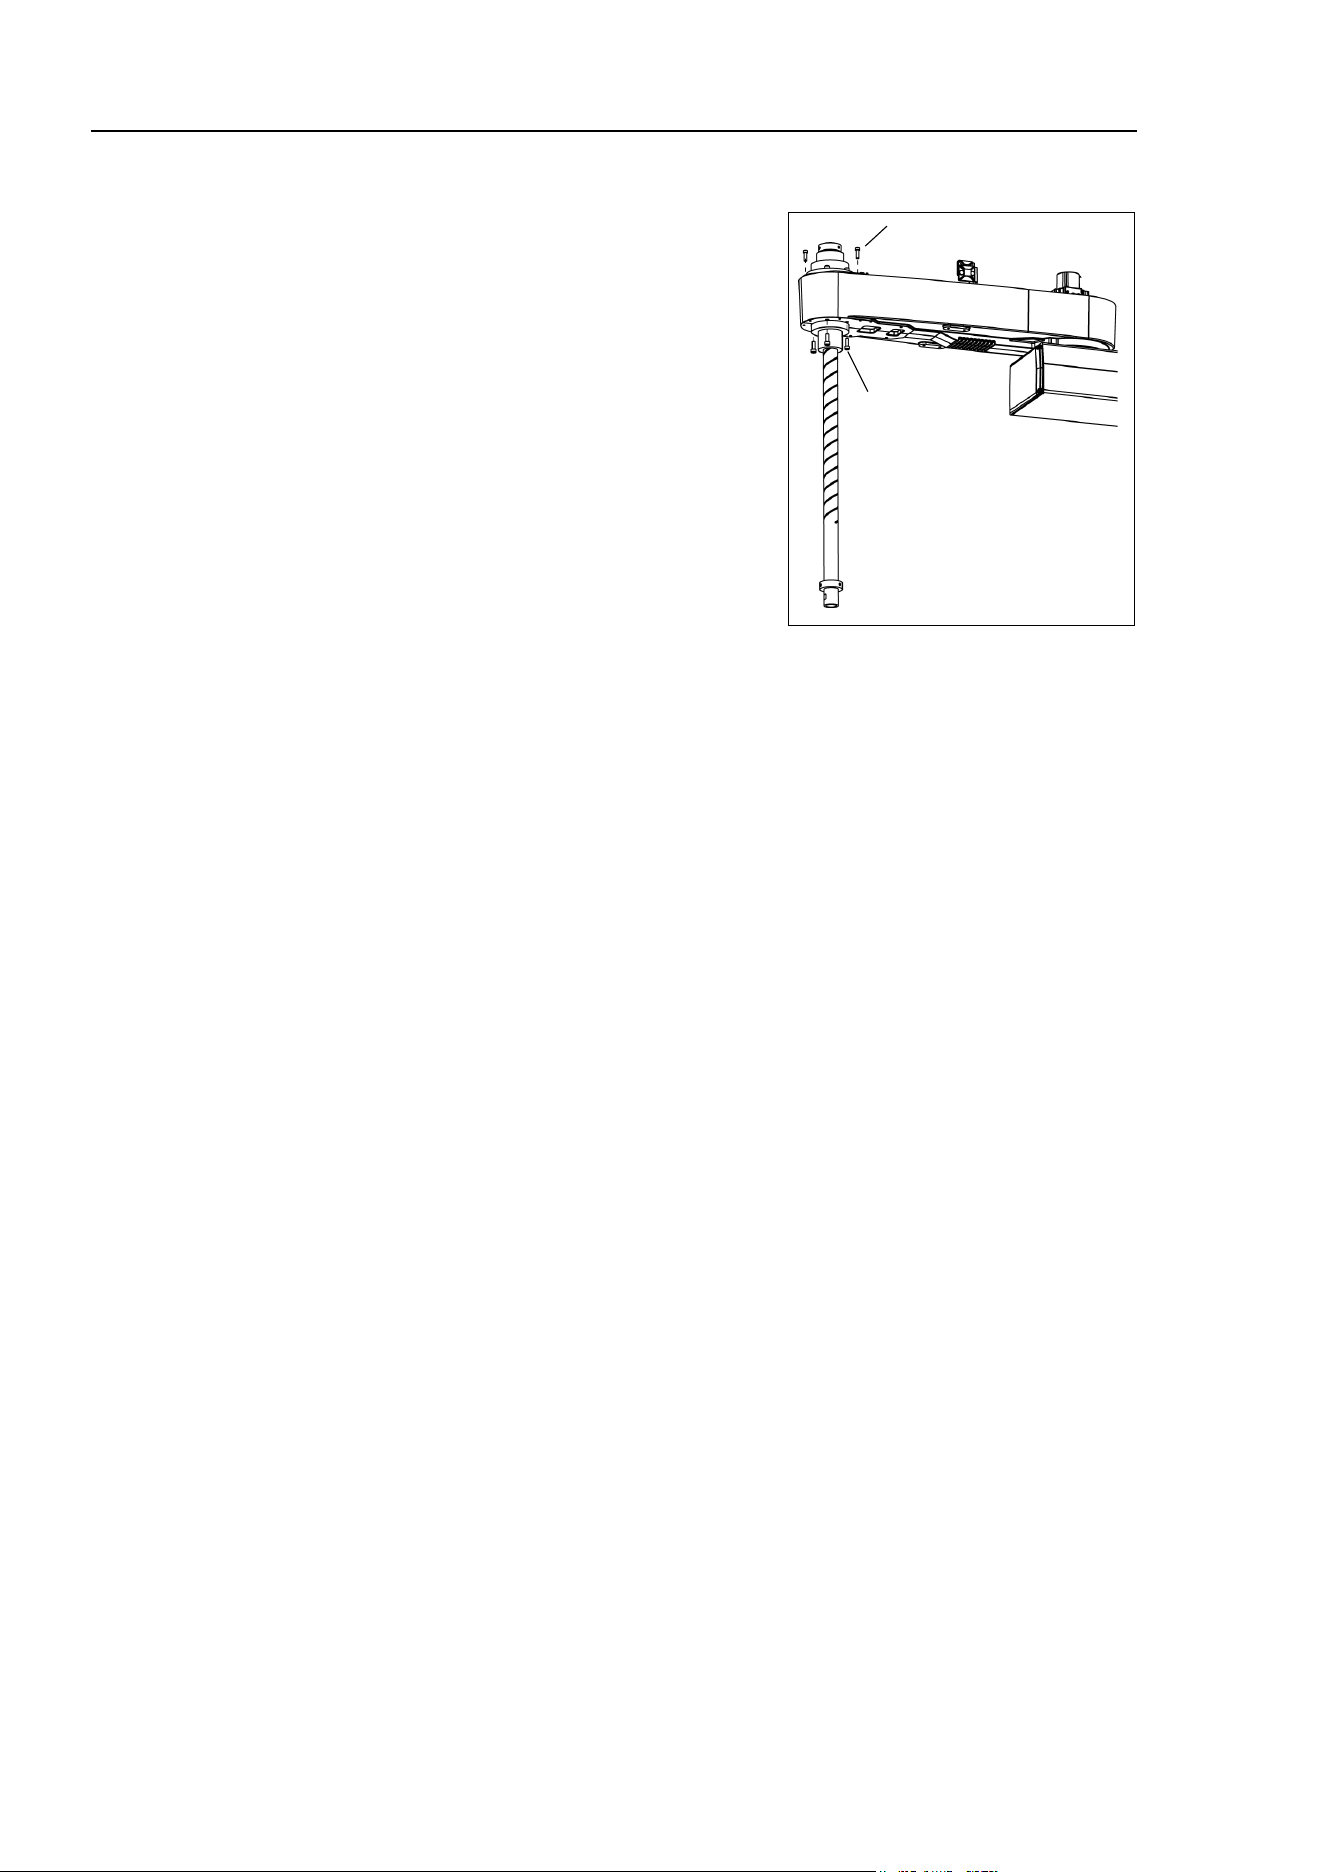
Maintenance 10. Ball Screw Spline Unit
152 L
S20-B Rev.4
Ball Screw
Spline Unit
Installation
(1)
Insert a new ball screw spline unit in the Arm #2.
(2)
Secure the spline nut from the bottom side of
the Arm #2.
4-M5×15
3-M4×15
(3)
Mount the following.
Joint #3 motor unit Joint #4 motor unit U belt Z belt
For details, refer to the following manuals:
Maintenance 7.1 Replacing Joint #3 Motor
Maintenance 8.1 Replacing Joint #4 Motor
(4)
Mount the Arm Top Cover and Arm Bottom Cover.
For details, refer to
Maintenance: 3. Covers.
(5)
Grease the shaft.
For details, refer to Maintenance: 10.1 Greasing the Ball Screw Spline Unit.
(6)
For the Cleanroom-model, mount the bellows.
For details, refer to Maintenance: 9. Bellows.
(7)
Mount the end effector, cables, and tubes.
(8)
Perform the calibration of Joints #3, #4.
For details, refer to Maintenance: 13. Calibration.
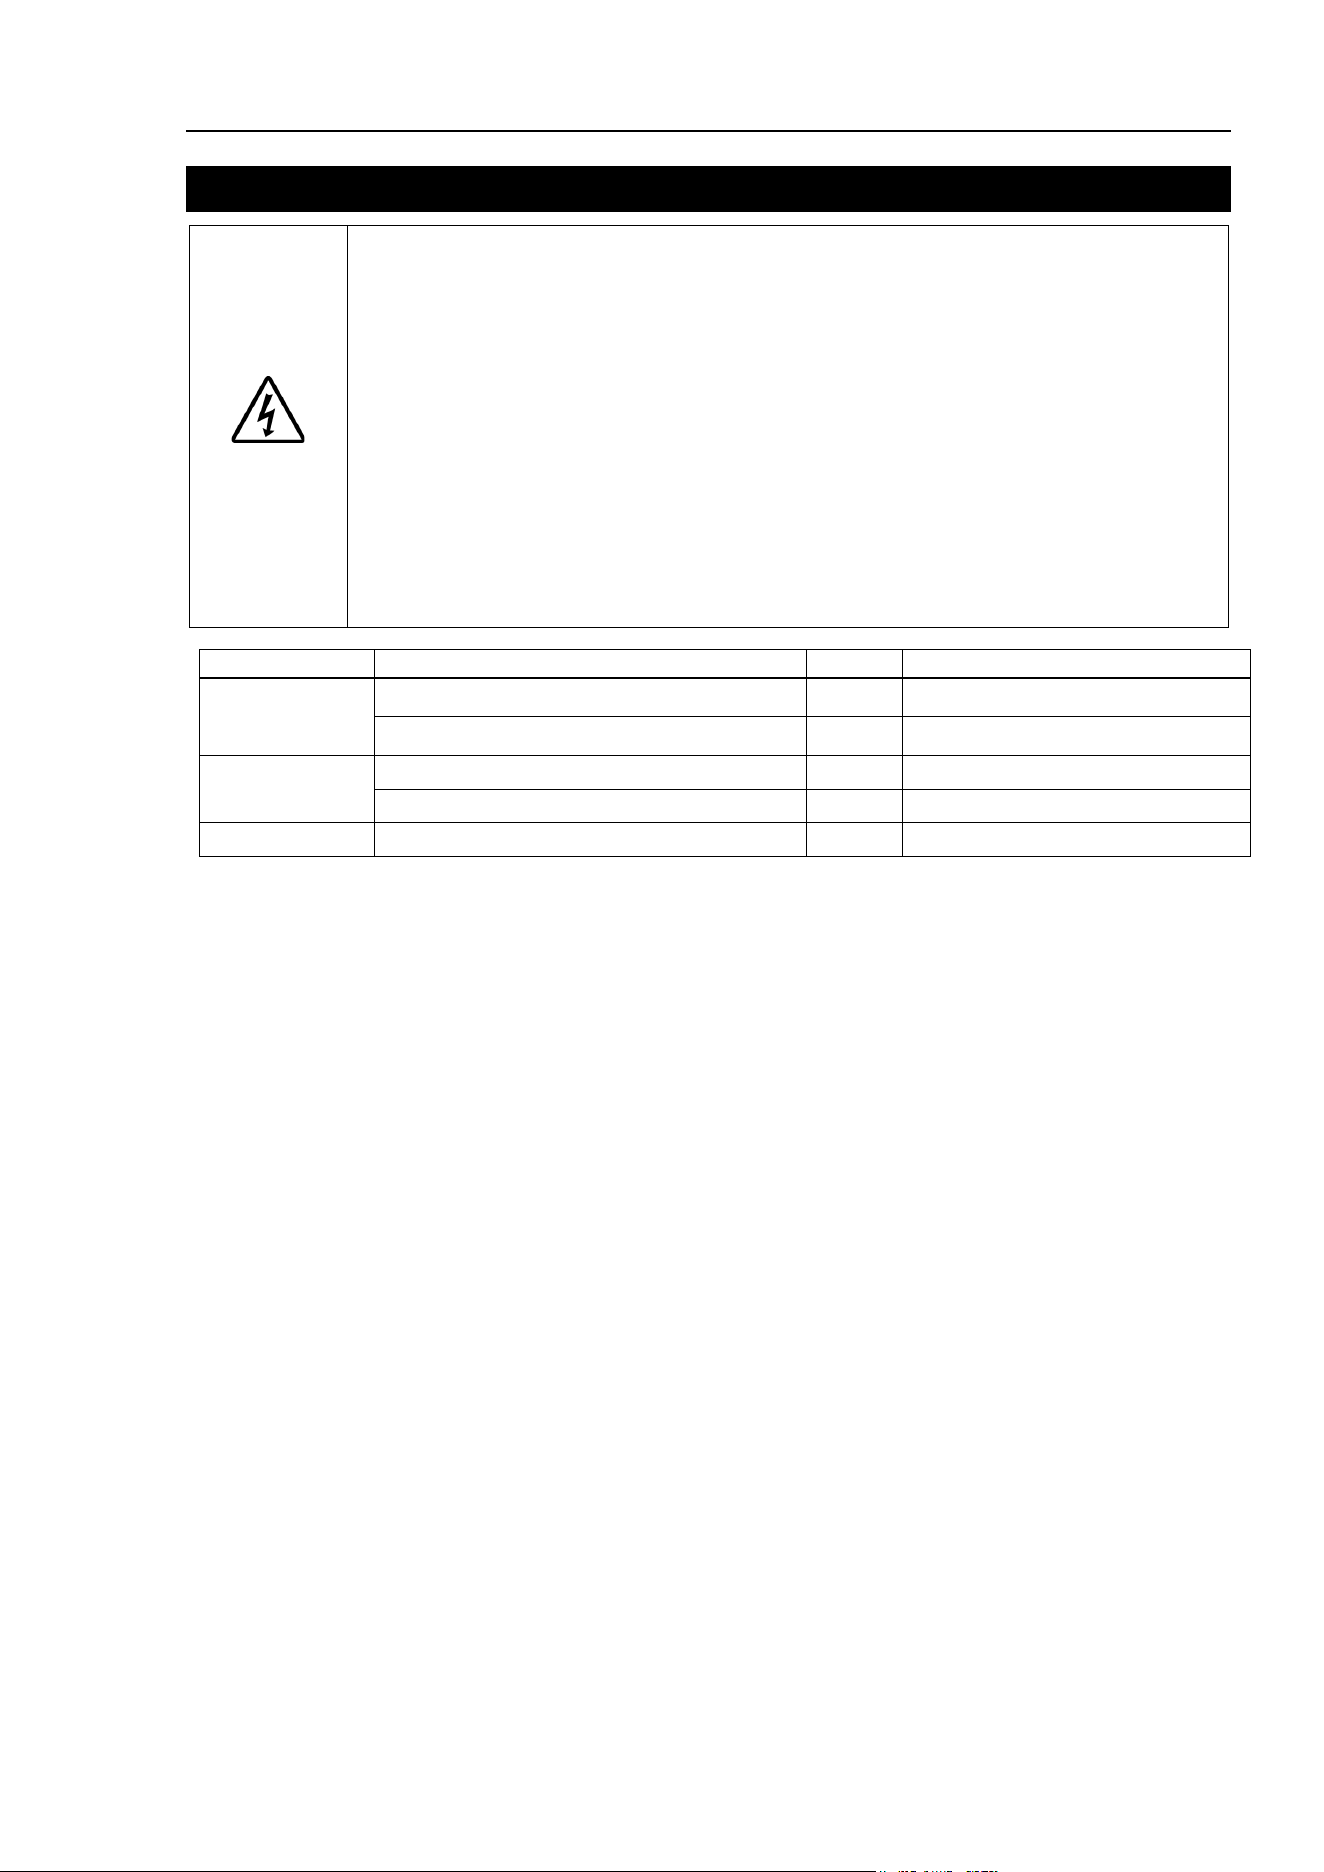
Maintenance 11. Boards
LS20-B Rev.4 153
11. Boards
WARNING
■
Do not connect or disconnect the motor connectors while the power to the robot
system is turned ON. Connecting or disconnecting the motor connectors
with
the power ON is extremely hazardous and may result
in serious bodily injury as
the Manipulator may mo
ve abnormally, and also may result in electric shock
and/or malfunction of the robot system.
■
To shut off power
to the robot system, disconnect the power plug from the power
source. Be sure to connect the AC power cable to a power receptacle.
DO NOT connect it directly to a factory power source.
■
Before performing any replacement procedure, turn OFF the Controller and
related equipment,
and then disconnect the power plug from the power source.
Performing any replacement procedure with the power ON is extremely hazardous
and may result in
electric shock and/or malfunction of the robot system.
Name
Qty.
Note
Maintenance
parts
Converter board 1 2196970
Control board
1
2196966
Tools
Nippers
1
For cutting wire tie
Cross-point screwdriver (#1)
1
Material
Wire tie
1
For fixing cables
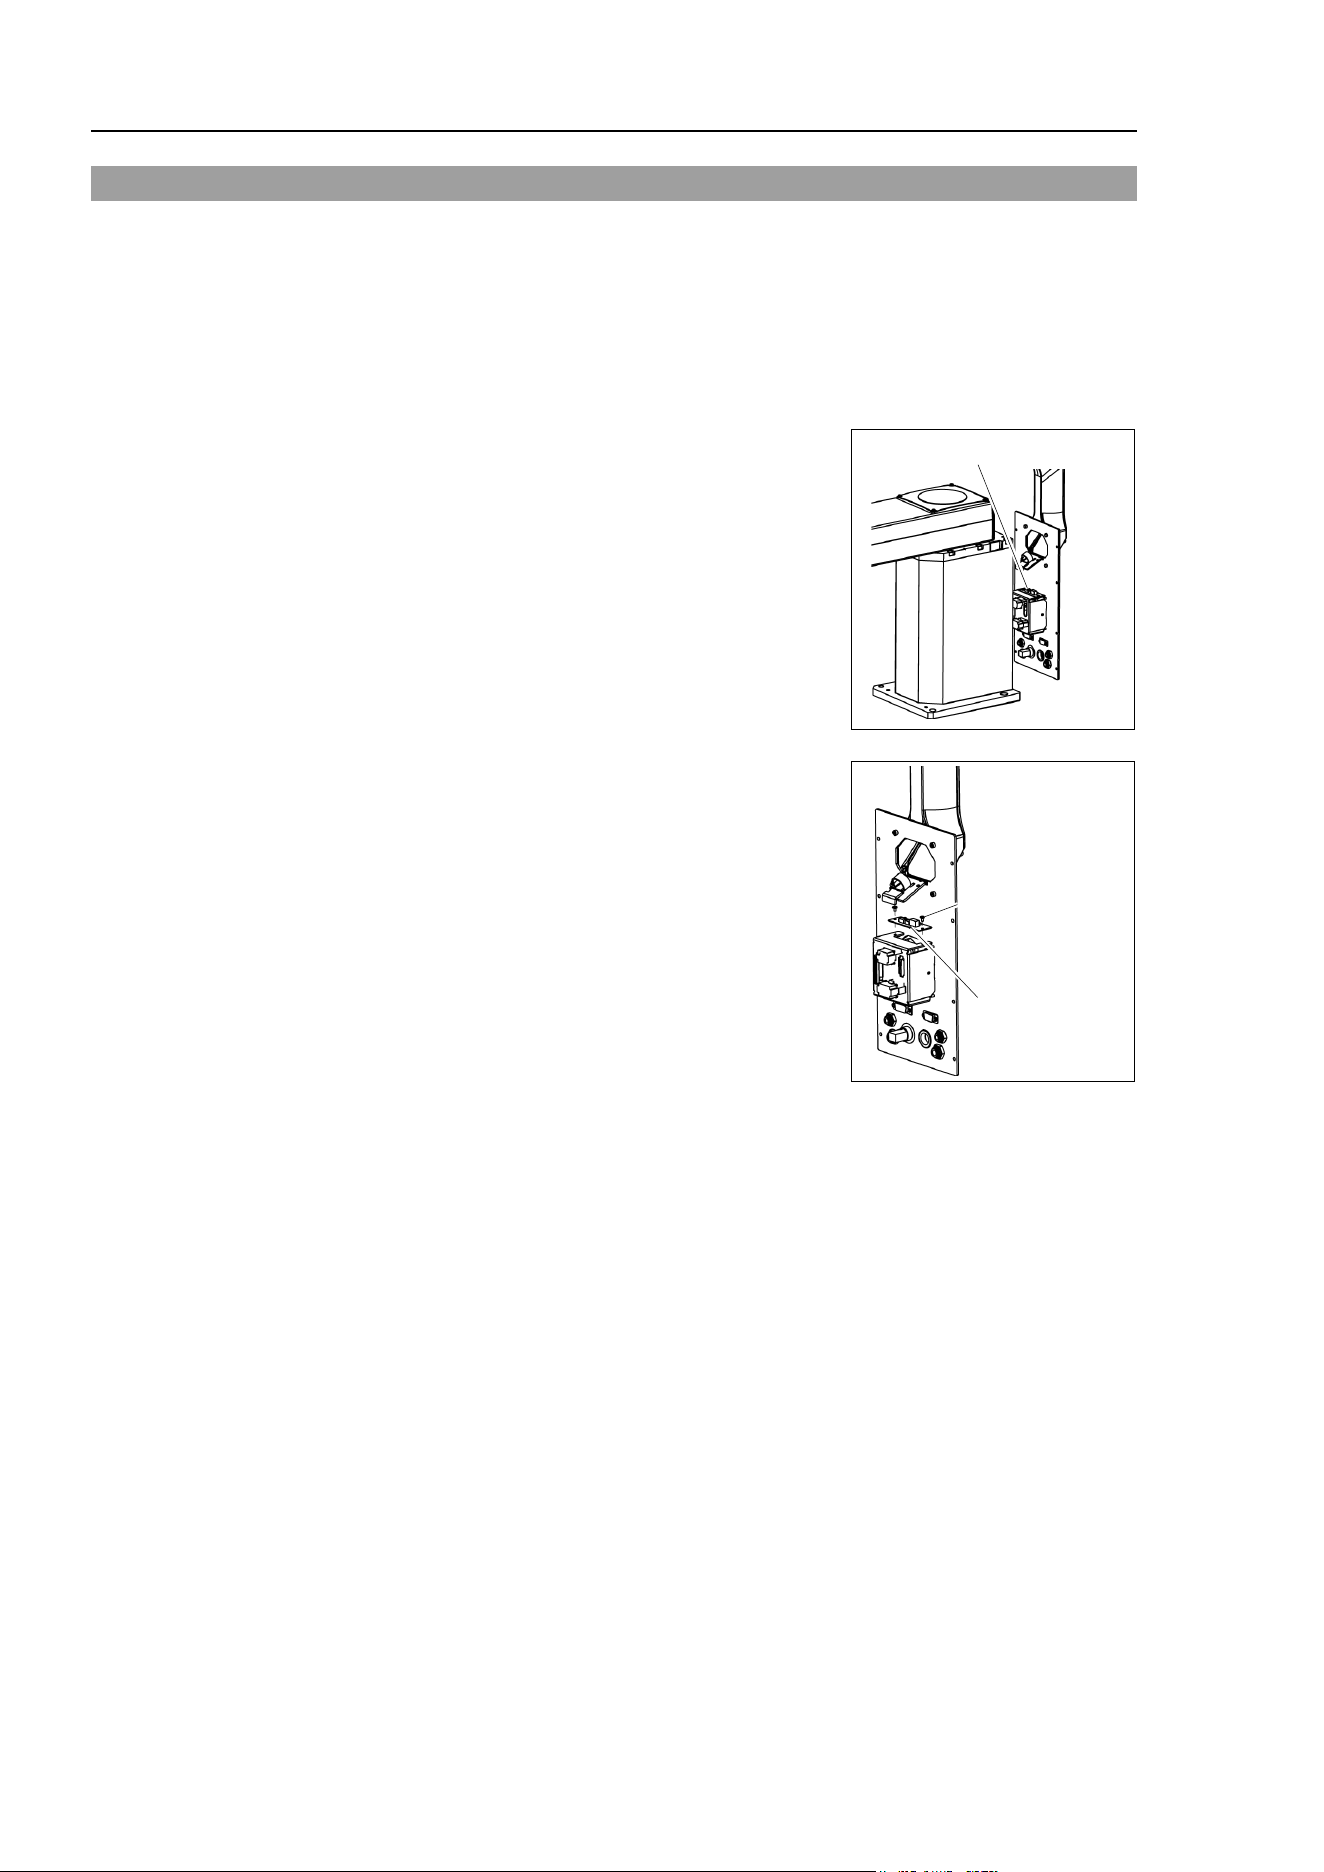
Maintenance 11. Boards
154 L
S20-B Rev.4
11.1 Replacing the Converter Board
Board which supplies power to the encoder of the motor is mounted inside the base of the
manipulator. If the board gets damage, the manipulator will not operate.
Converter board
Removal
(1)
Turn OFF the
controller.
(2)
Remove the Connector Plate.
For details, refer to Maintenance: 3.4 Connector Plate.
(3)
Disconnect
the following connectors which are
connected to the converter board.
Connectors: CV11, CV12, CV13
Converter Board
(4)
Remove the converter board from the
mount base.
Binding head small screws:
2-M3 (cross-point screwdriver)
Converter
Board
2-M3
Binding head
small screws
C
onverter board
Installation
(1)
Mount the converter board on the mount base.
Binding head small screws: (2-M3)
(2)
Connect the following
connectors to the converter board.
Connectors: CV11, CV12, CV13
(3)
Mount the Connector Plate.
F
or details, refer to Maintenance: 3.4 Connector Plate.
(4)
Turn ON the Controller.
(5)
Make sure no errors occur in all joints.
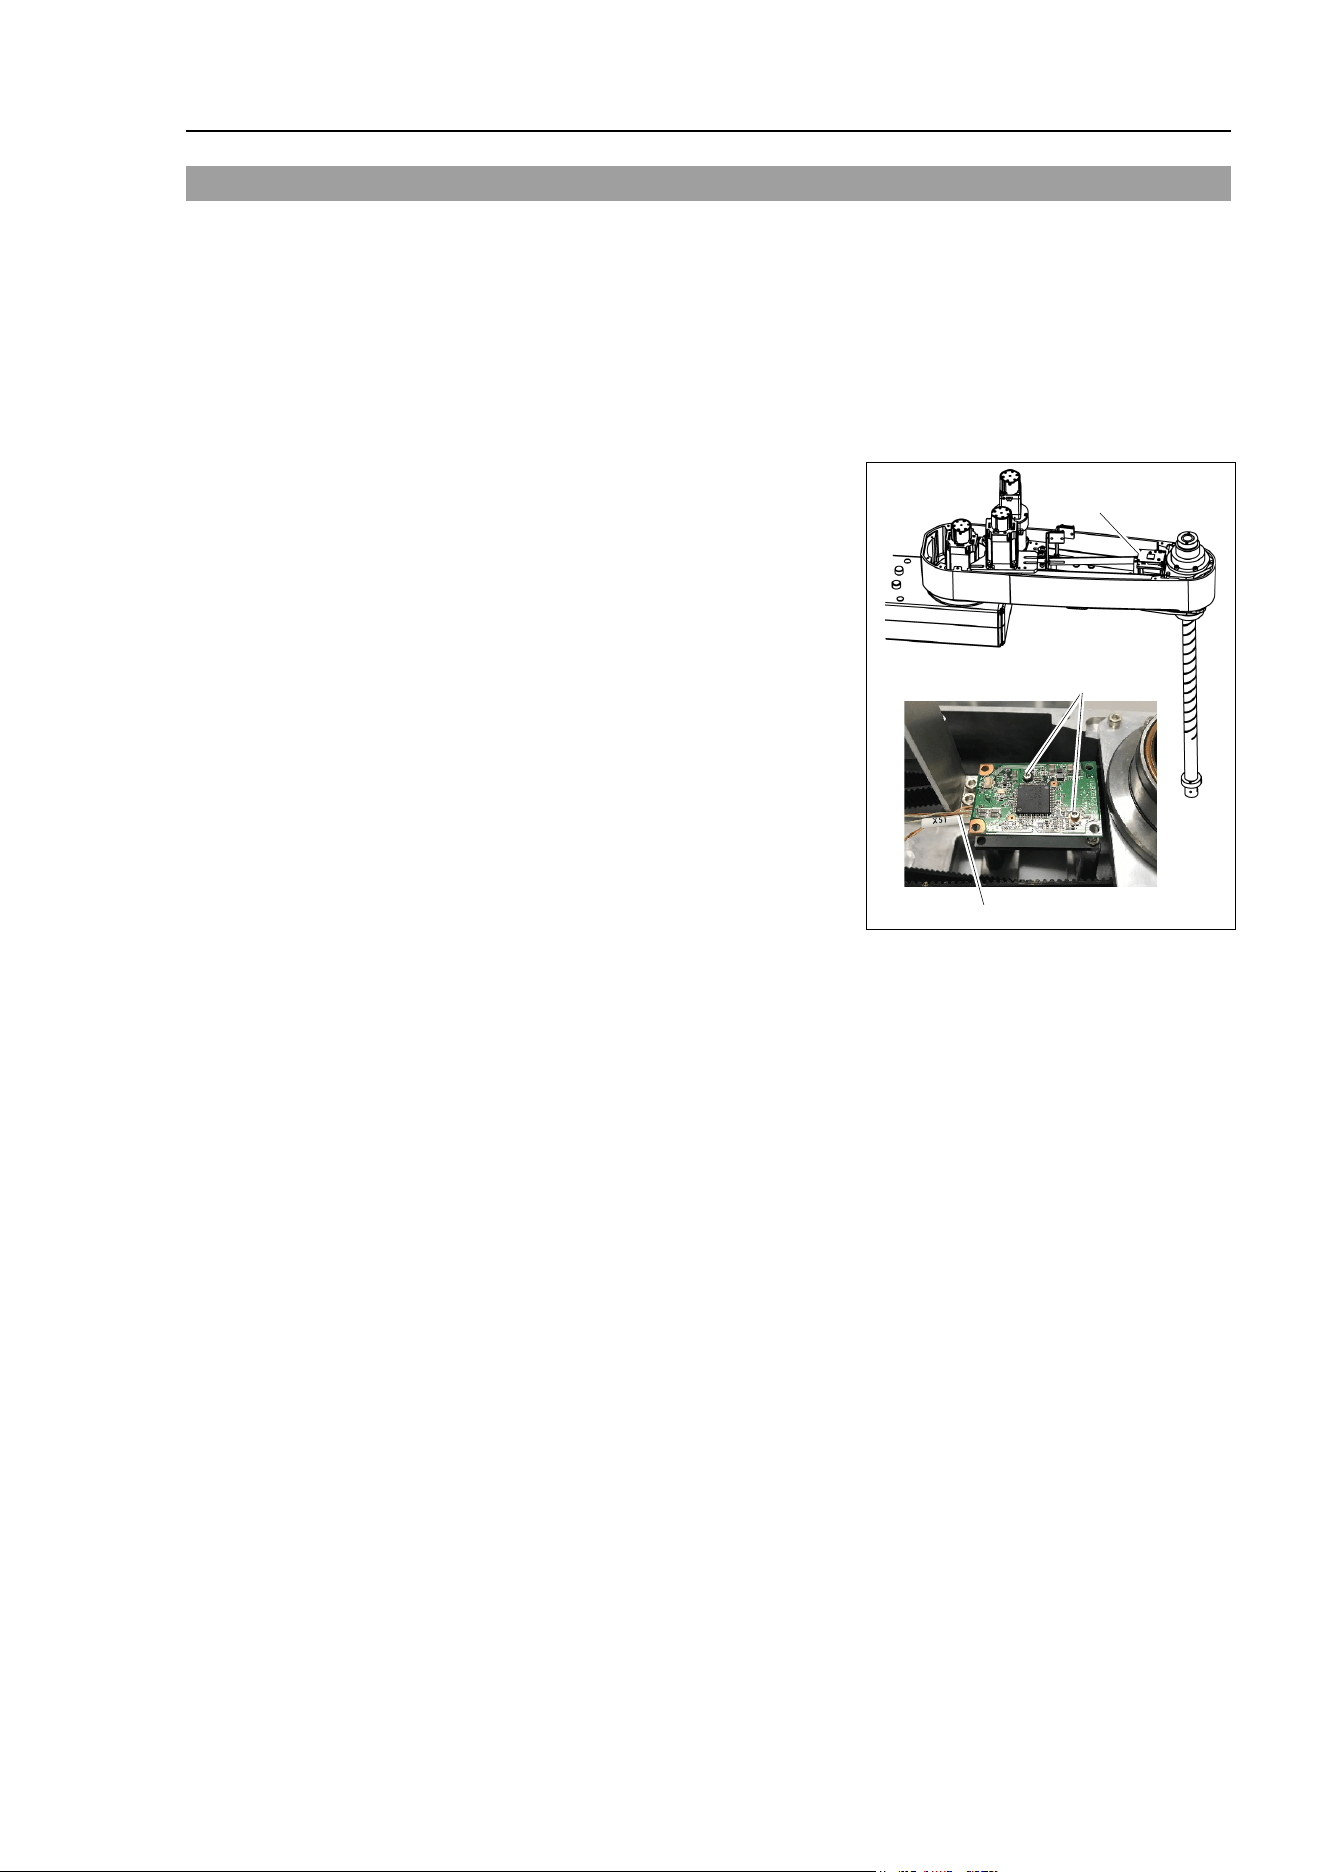
Maintenance 11. Boards
LS20-B Rev.4 155
11.2 Replacing the Control Board
Control
Board
Removal
(1)
Turn OFF the controller.
(2)
Remove the Arm Top Cover.
For details, refer to Maintenance: 3.1 Arm Top Cover.
(3)
Disconnect the
following connector.
Connector: X51
(4)
Remove the Control
board.
2-M2×16
Pan head screw
Control Board
Connector
Control Board
Installation
(1)
Mount a new Control board.
Be careful of the board direction.
(Check the board direction by
the connector
position.)
(2)
Connect
the following connector.
Connector: X51
(3)
Mount the Arm Top Cover.
For details, refer to Maintenance: 3.1 Arm Top Cover.
(4)
Turn ON the controller.
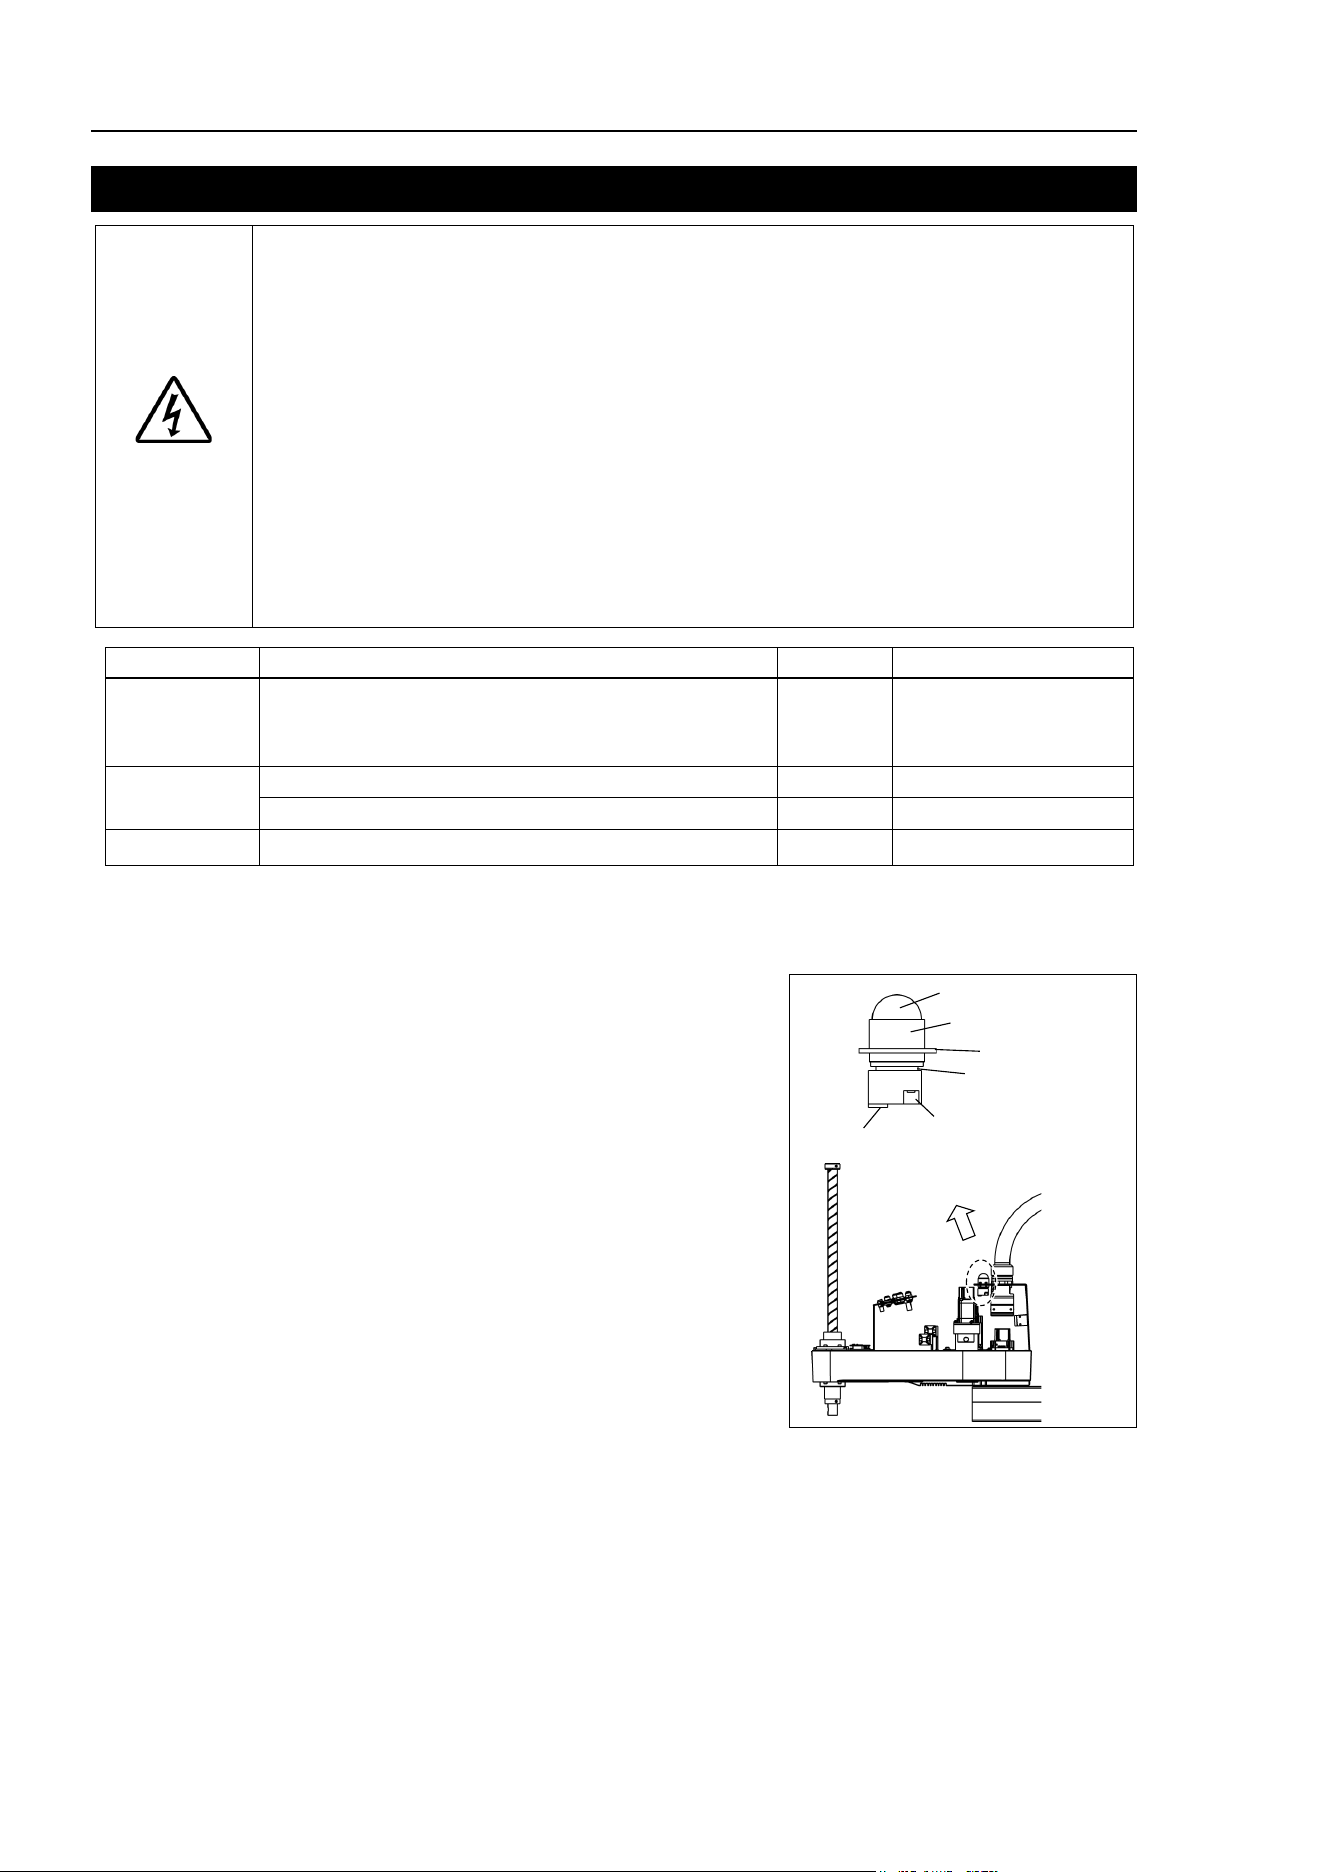
Maintenance 12. LED Lamp
156 L
S20-B Rev.4
12. LED Lamp
W
ARNING
■
Do not connect or disconnect the motor connectors while the power to the robot
system is turned ON. Connecting or disconnecting the motor connectors
with
the power ON is extremely hazardous and may result
in serious bodily injury as
the Manipulator may mo
ve abnormally, and also may result in electric shock
and/or malfunction of the robot system.
■
To shut off power
to the robot system, disconnect the power plug from the power
source. Be sure to connect the AC power cable to a power receptacle.
DO NOT connect it directly to a factory power source.
■
Before performing any replacement procedure, turn OFF the Controller and
related equipment,
and then disconnect the power plug from the power source.
Performing any replacement procedure with the power ON is extremely hazardous
and may result in
electric shock and/or malfunction of the robot system.
Name
Qty.
Note
Maintenanc
e
parts
LED Lamp 1
2077258
Tools
Cross-point screwdriver
1
For wire removal
Nippers
1
Material
Wire tie 1
LED Lamp
Removal
(1)
Remove the
Arm Top Cover.
For details, refer to Maintenance: 3.1 Arm Top Cover.
(2)
Disconnect the X1 and X2 terminals from the
LED.
X2 Terminal (opposite side)
X1 Terminal
Lens
Lens Holder
Ring
LED
(3)
Turn the lens counter
clockwise
to remove.
Then, turn the lens holder counter
clockwise to
remove.
(4)
Remove the LED and ring from the User Plate.
LED Lamp
Installation
(1)
Connect the X1 and X2 terminals to the LED.
Each terminal must be connected to the same
terminal number on the LED.
(2)
Put the User Plate between the ring and lens
holder, and then secure the LED to the cover.
(3)
Mount the lens.
(
4)
Install the
Arm Top Cover.
For details, refer to Maintenance: 3.1 Arm Top Cover.
Maintenance 13. Calibration
LS20-B Rev.4 157
13. Calibration
13.1 About Calibration
After parts have been replaced (motors, reduction gear units, timing belts, etc.), the
Manipulator cannot execute the positioning properly because a mismatch exists between the
origin stored in each motor and its corresponding origin stored in the Controller.
After replacing the parts, it is necessary to match these origins.
The process of aligning the two origins is called “Calibration”. Note that calibration is not
the same as teaching*.
*: “Teaching” means to teach the Controller coordinate points (including poses) anywhere
in the operating area of the Manipulator.
WARNING
■
To ensure safety, a safeguard must be installed for the robot
system.
For details on the safeguard, refer to EPSON RC+ User
’s Guide: 2.4 Installation
and Design Precautions
.
■
Before operating the robot system, make sure that no one is inside the
safeguard
ed area. The robot system can be operated in the mode for teaching
even when someone is inside the safeguard
ed area.
The motion of the Manipulator is always in restricted (low speeds and low power)
status to secure the safety of an operator. However, operating the robot system
while someone is inside the safeguar
ded area is extremely hazardous and may
result in serious safety problems in case that the Manipulator moves
unexpectedly.
Command Input
Calibration procedures include the process to input commands. Select EPSON RC+ menu-
[Tools]-[Command Window] to use the command window.
The information above is omitted in the calibration procedure.
Jog Motion
The process to set the jog motion is included in the [Jog & Teach] page of the Robot Manager.
Select EPSON RC+ menu-[Tools]-[Robot Manager] and select the [Jog & Teach] tab to use
the [Jog & Teach] page.
The page above is indicated as [Jog & Teach] in the calibration procedure.
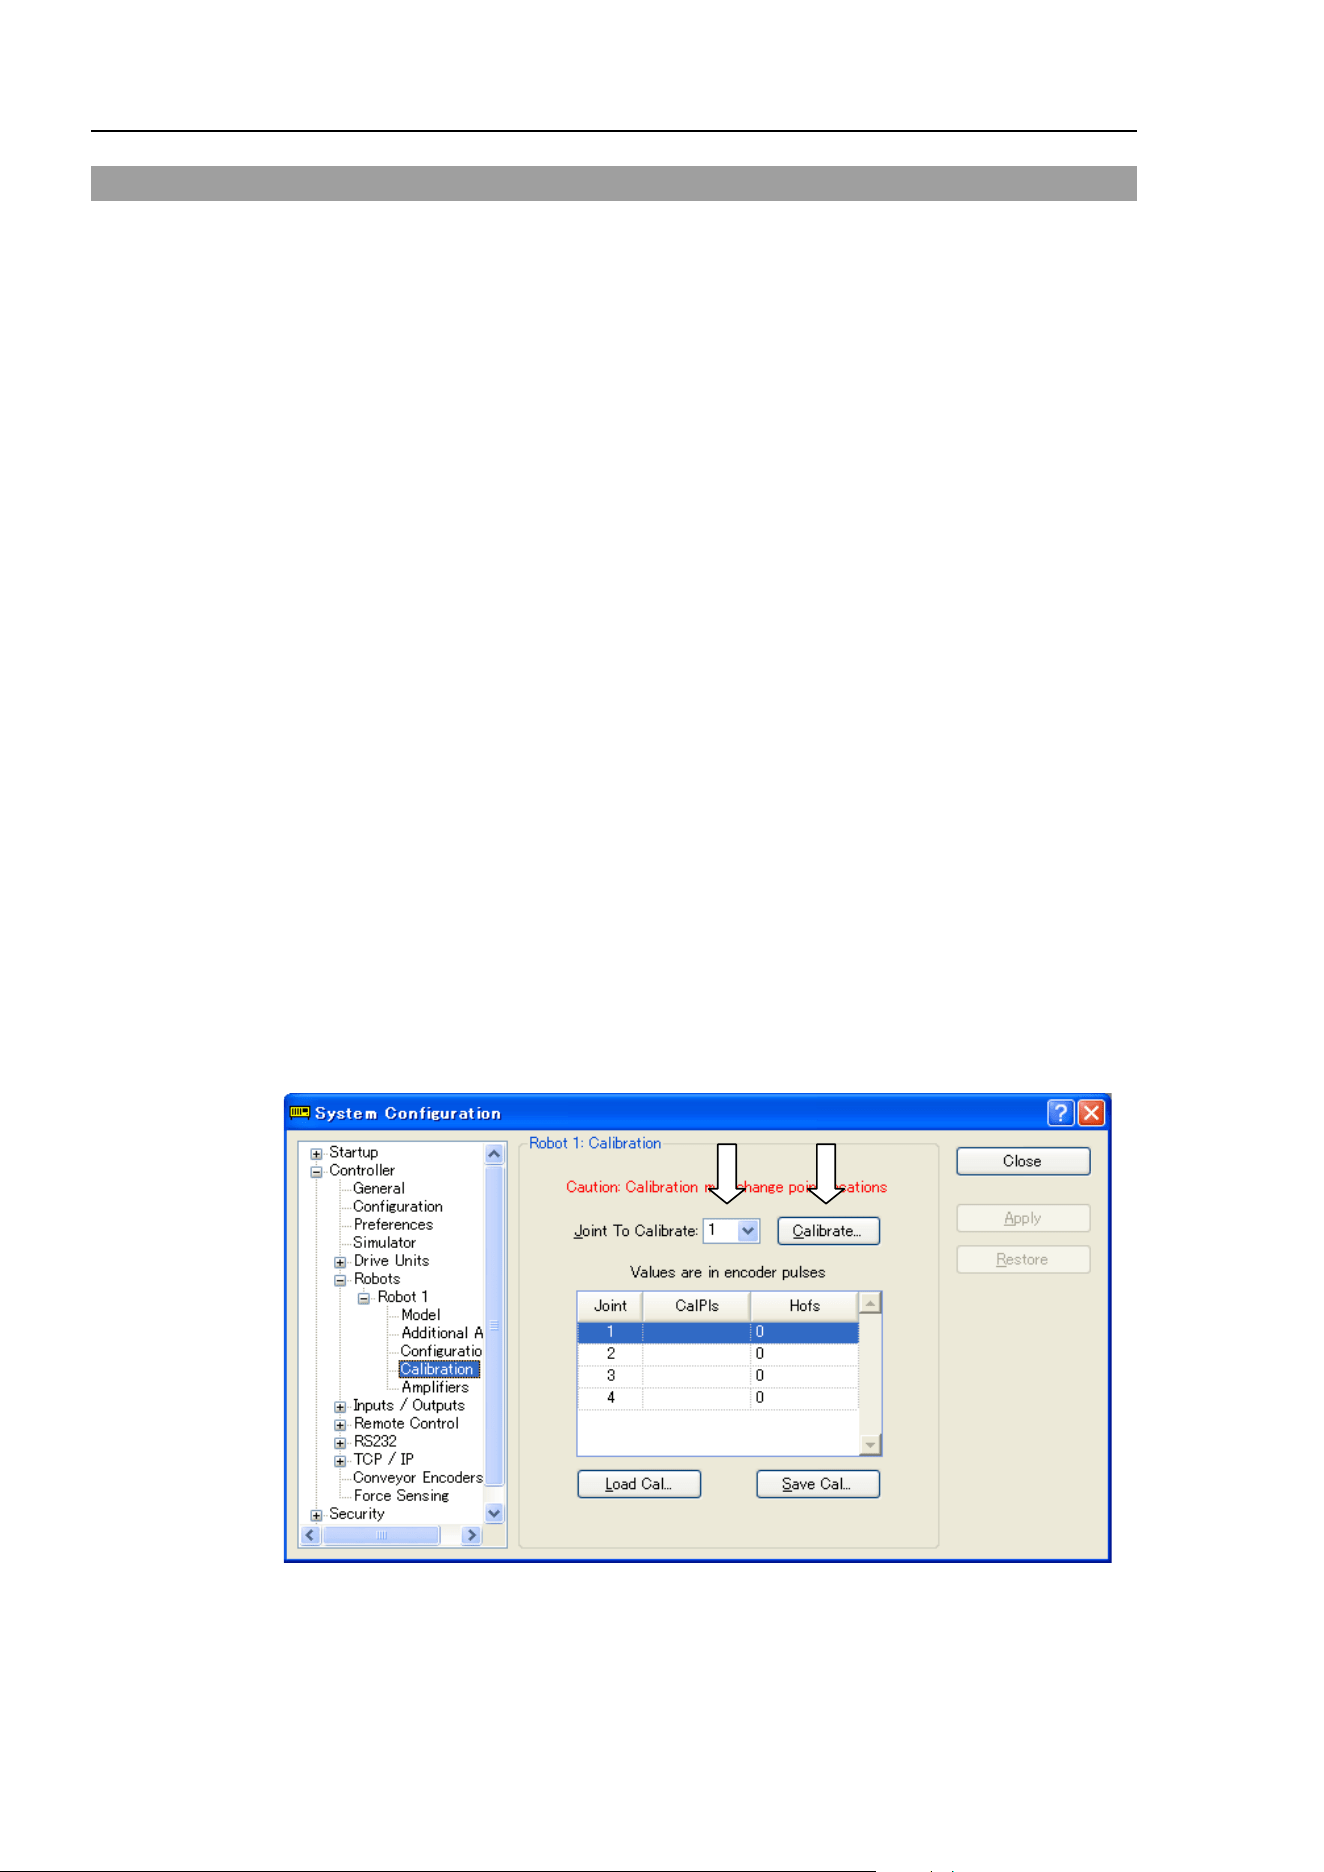
Maintenance 13. Calibration
158 LS20-B Rev.4
13.2 Calibration Procedure
EPSON RC+ has a wizard for calibration.
This section indicates the calibration using the calibration wizard of EPSON RC+.
The same calibration procedure is used for each joint.
The follow the steps below are calibration using Joint #1. Follow the steps below to
calibrate other joints.
When coordinates for the Manipulator working point require calculation, it is important for
Joint #2 to be calibrated accurately. Execute the procedure in “Calibration Using Right /
Left Arm Orientations” to accurately calibrate Joint #2. For details, refer to Maintenance:
13.3 Accurate Calibration of Joint #2.
When calibrating Joint #4, you must calibrate Joint #3 and #4 at the same time. Yo u cannot
calibrate Joint #4 alone because of the structure of the Manipulator.
If Err9716 or 5016 (Power supply failure of the absolute encoder. Replace the battery.
Check the robot internal wiring) occurs, apply the procedure of 13.4 Calibration Procedure
without using Calibration Wizard - 3. Encoder Initialization and then, start the calibration
wizard.
The reference point (a point to check the accuracy) needs to be specified for calibration.
(1) Start the calibration wizard.
i. Select EPSON RC+ 7.0 menu - [Setup] to display the [System Configuration]
dialog.
ii. Select [Robots]-[Robot**] to display [Calibration].
iii. Select the joint and click the <Calibrate…> button.
NOTE
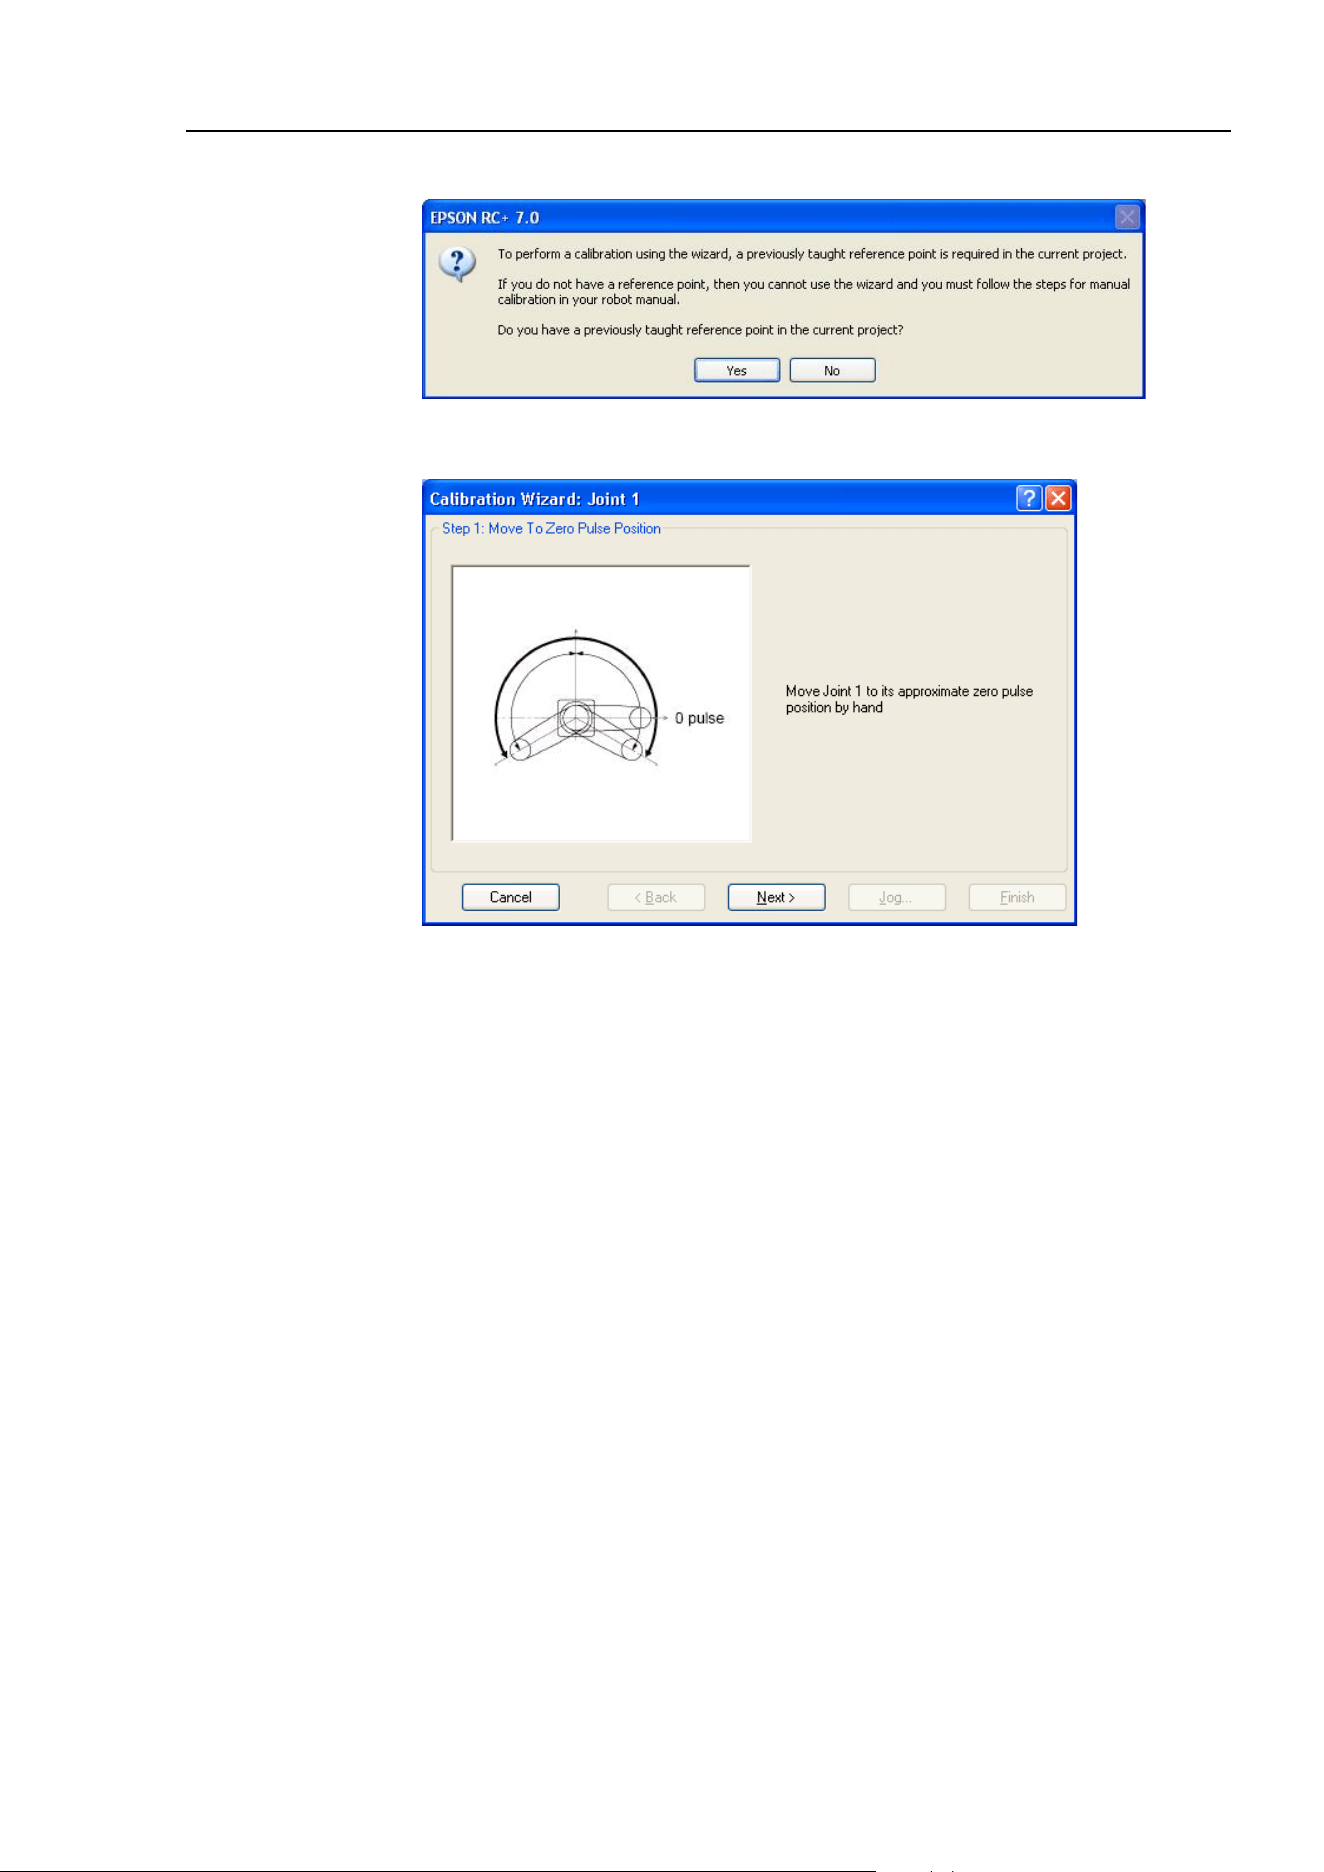
Maintenance 13. Calibration
LS20-B Rev.4 159
(2) Confirm the warning message and click the <Yes> button.
(3) Move the joint to calibrate manually to approximate zero position, as shown in the
dialog. After moving the joint click the <Next> button.
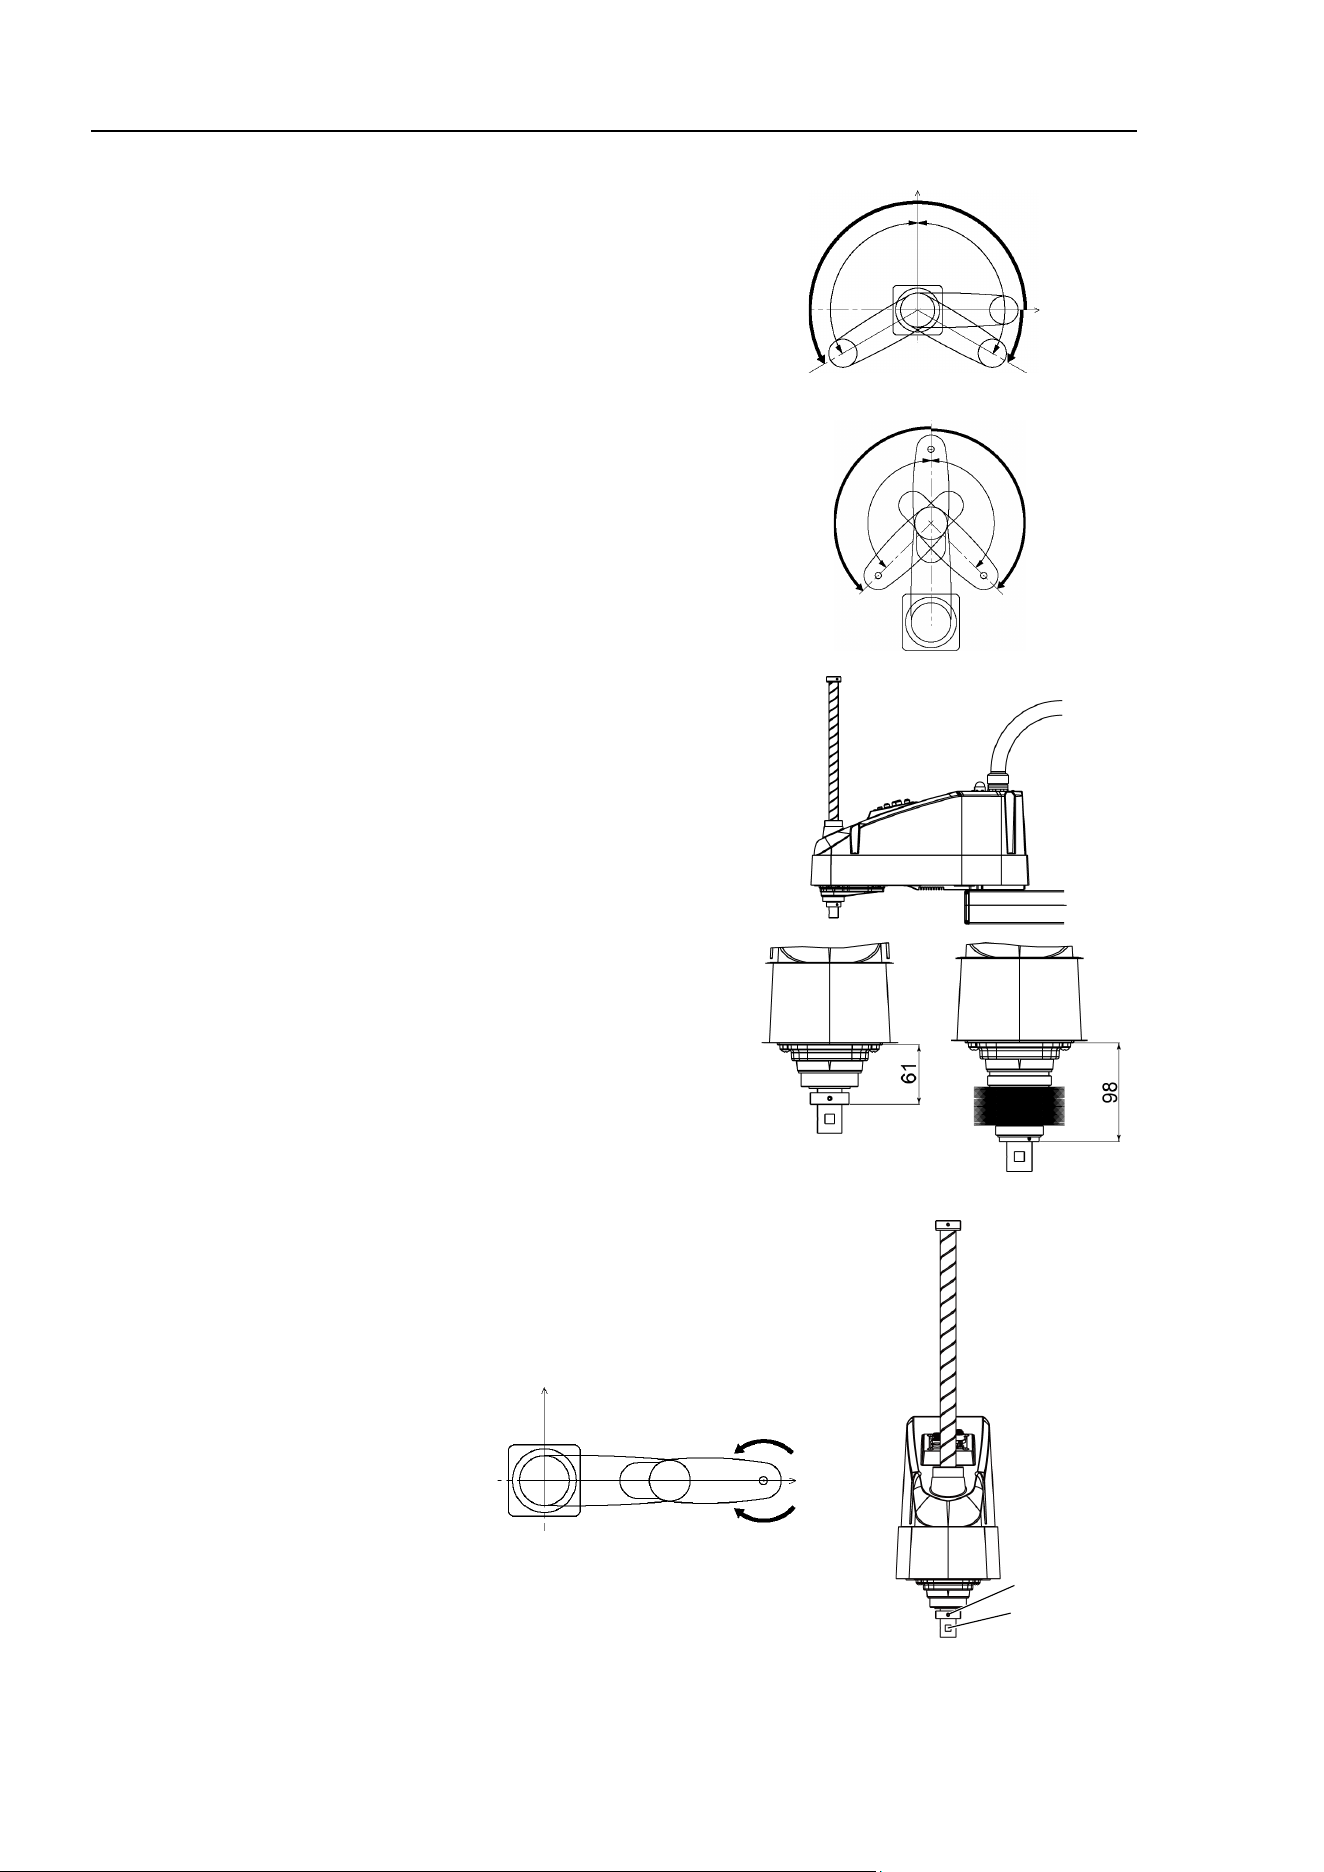
Maintenance 13. Calibration
160 LS20-B Rev.4
0 pulse position of Joint #1:
position aligned with X-axis in
Robot coordinate system
0 pulse
+
−
0 pulse position of Joint #2:
position where Arms #1 and #2
are in a straight line
(Regardless of the Joint #1
direction.)
0 pulse
+
−
0 pulse position of Joint #3:
upper limit position in motion
range
The height of Joint #3 depends on
manipulator model.
Standard model
Cleranroom model
0 pulse position of Joint #4:
position where the flat surface on the shaft (or
set screws of the mechanical stop on the
bottom) faces toward the tip of Arm #2
Flat surface
Set screws
0 pulse
+
−
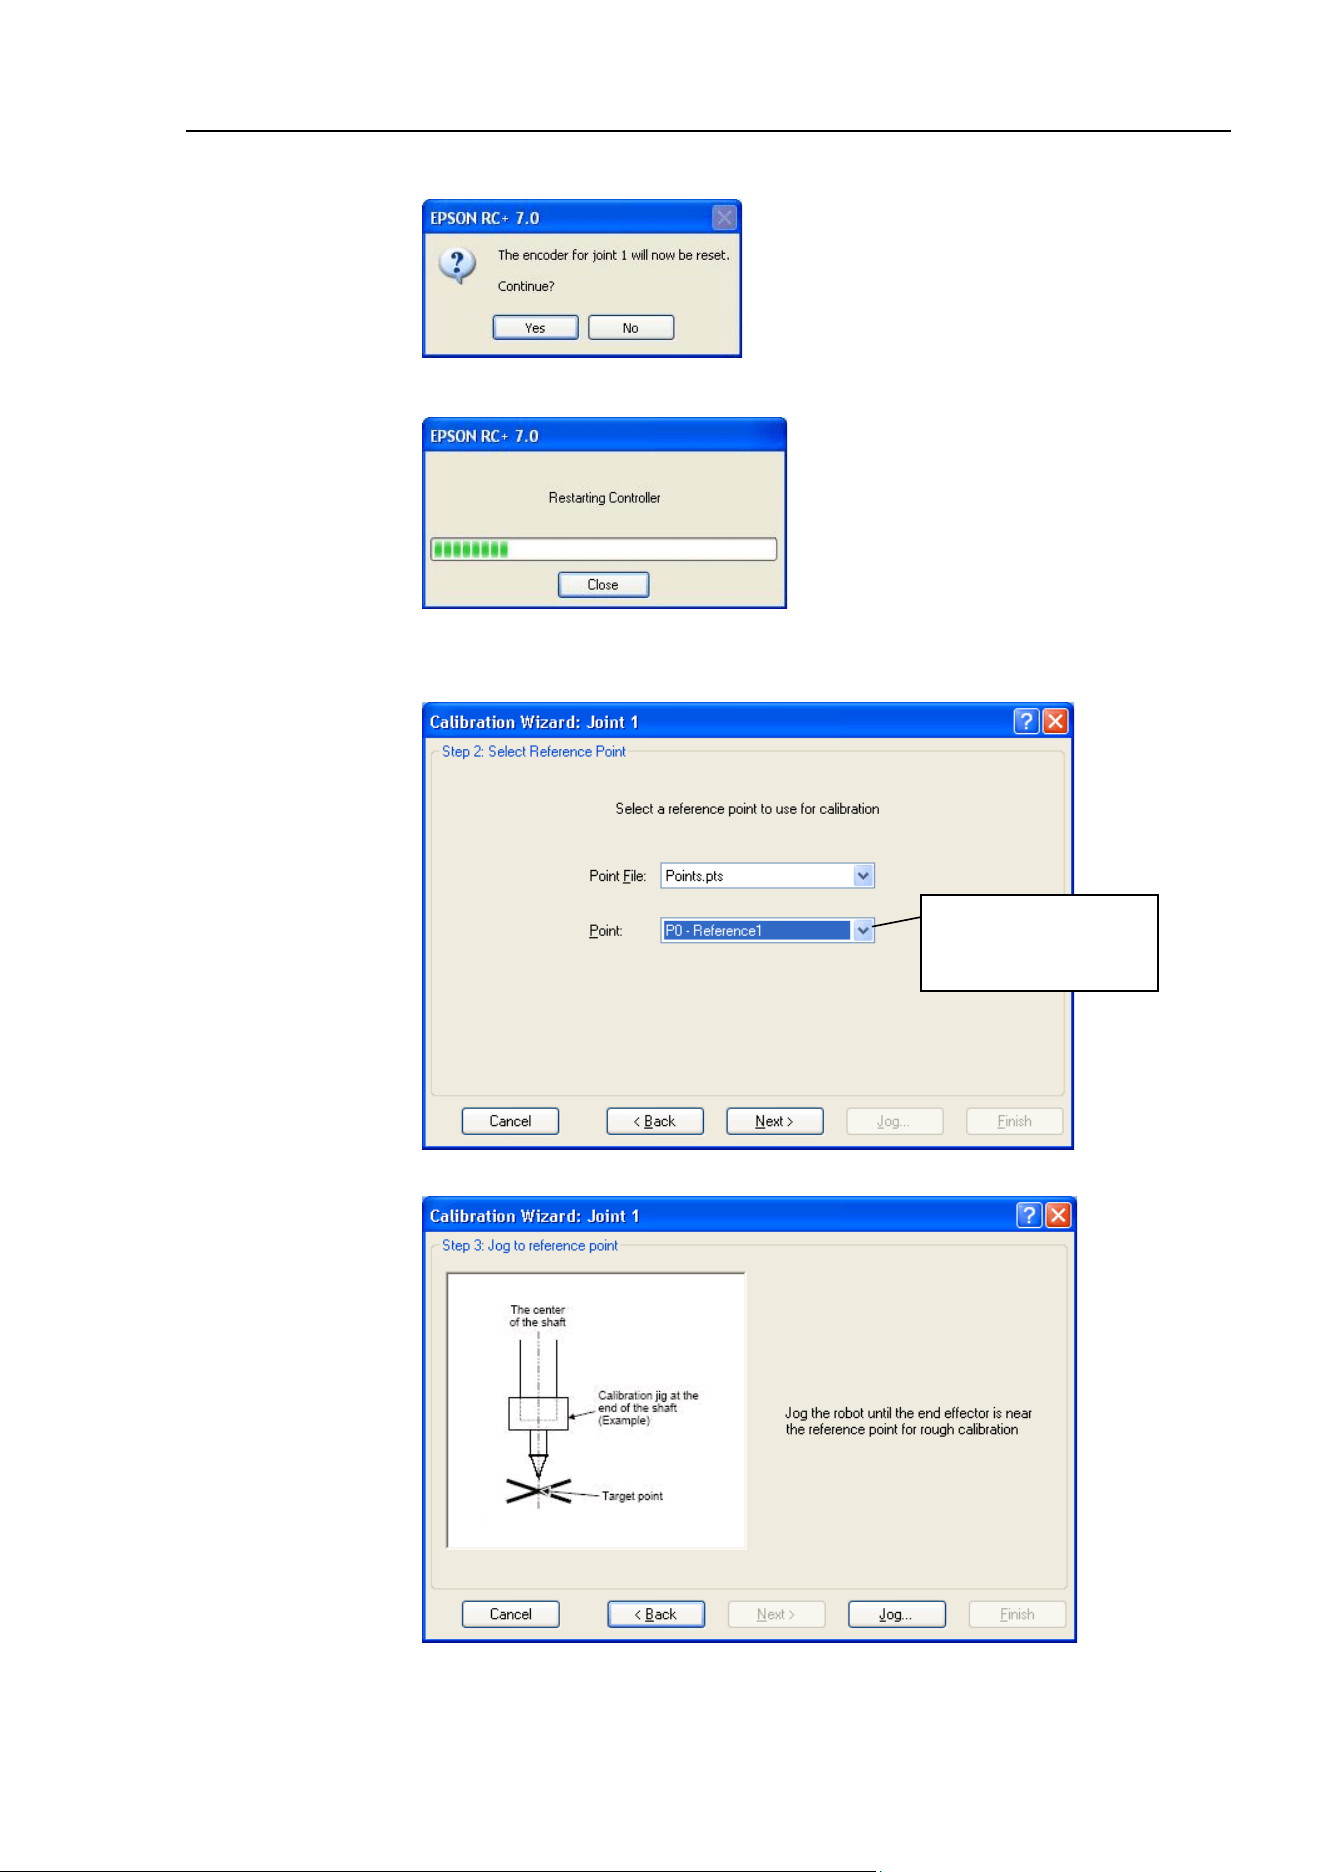
Maintenance 13. Calibration
LS20-B Rev.4 161
(4) Click the <Yes> button to reset the encoder.
(5) Reboot the Controller.
* This window will disappear when the Controller starts up.
(6) Select the reference point to use for calibration, and click the <Next> button.
Select a point from the
current points to use for
checking the accuracy.
(7) Click the <Jog…> button to display the [Jog & Teach] dialog.
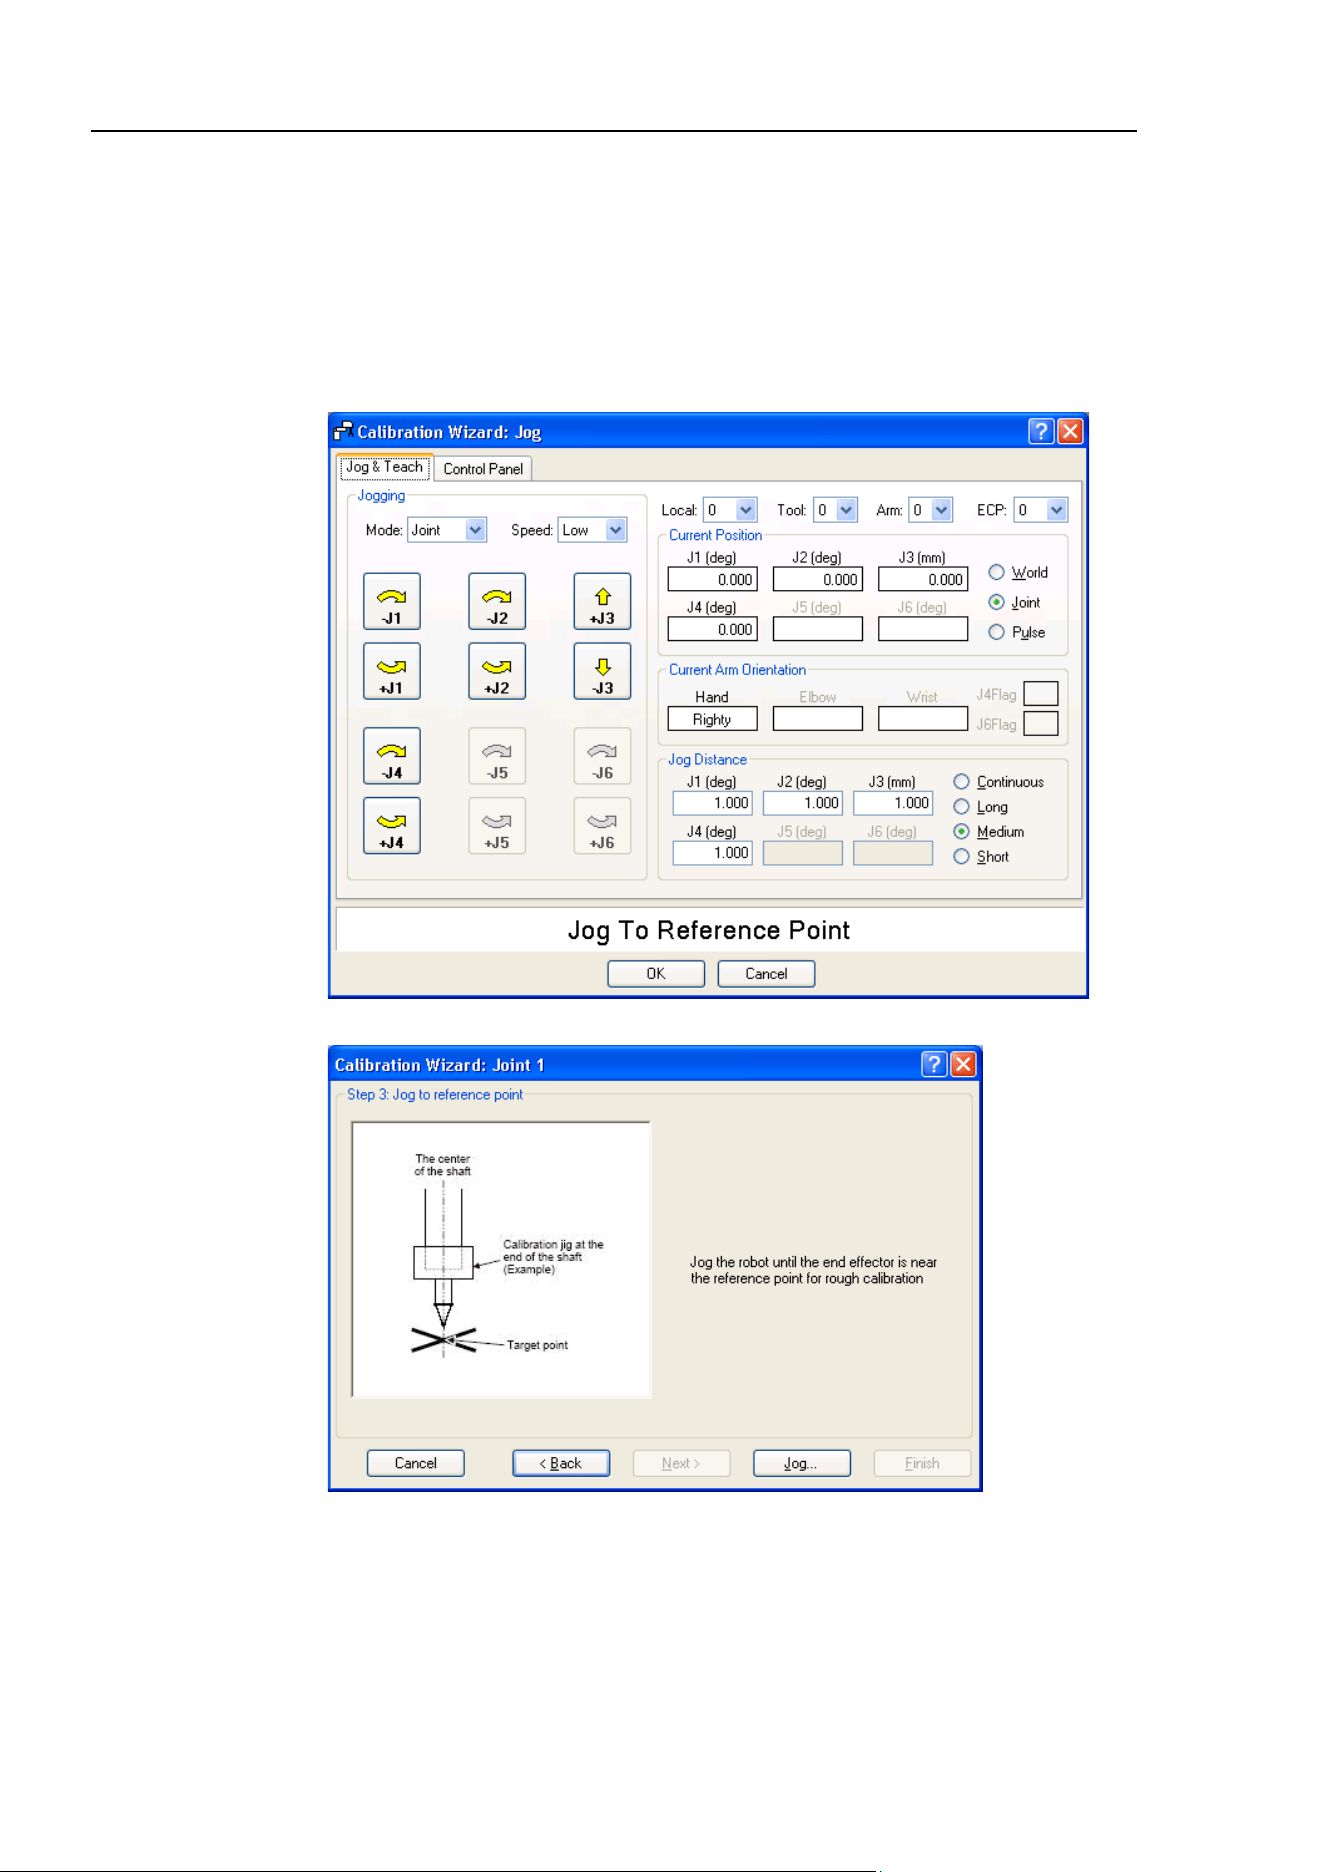
Maintenance 13. Calibration
162 LS20-B Rev.4
(8) Jog the end effector to approximate reference point in the [Jog & Teach] dialog for
rough calibration. Then click the <OK> button.
Before operating the robot, open the [Control Panel] and click on the <Motor ON>
button.
Move the end effector from the zero pulse position to the approximate reference point
where rough calibration will be executed at by the jog motion. Position gap may occur
if the end effector is not moved by the jog motion.
(9) Click the <Next> button.
NOTE
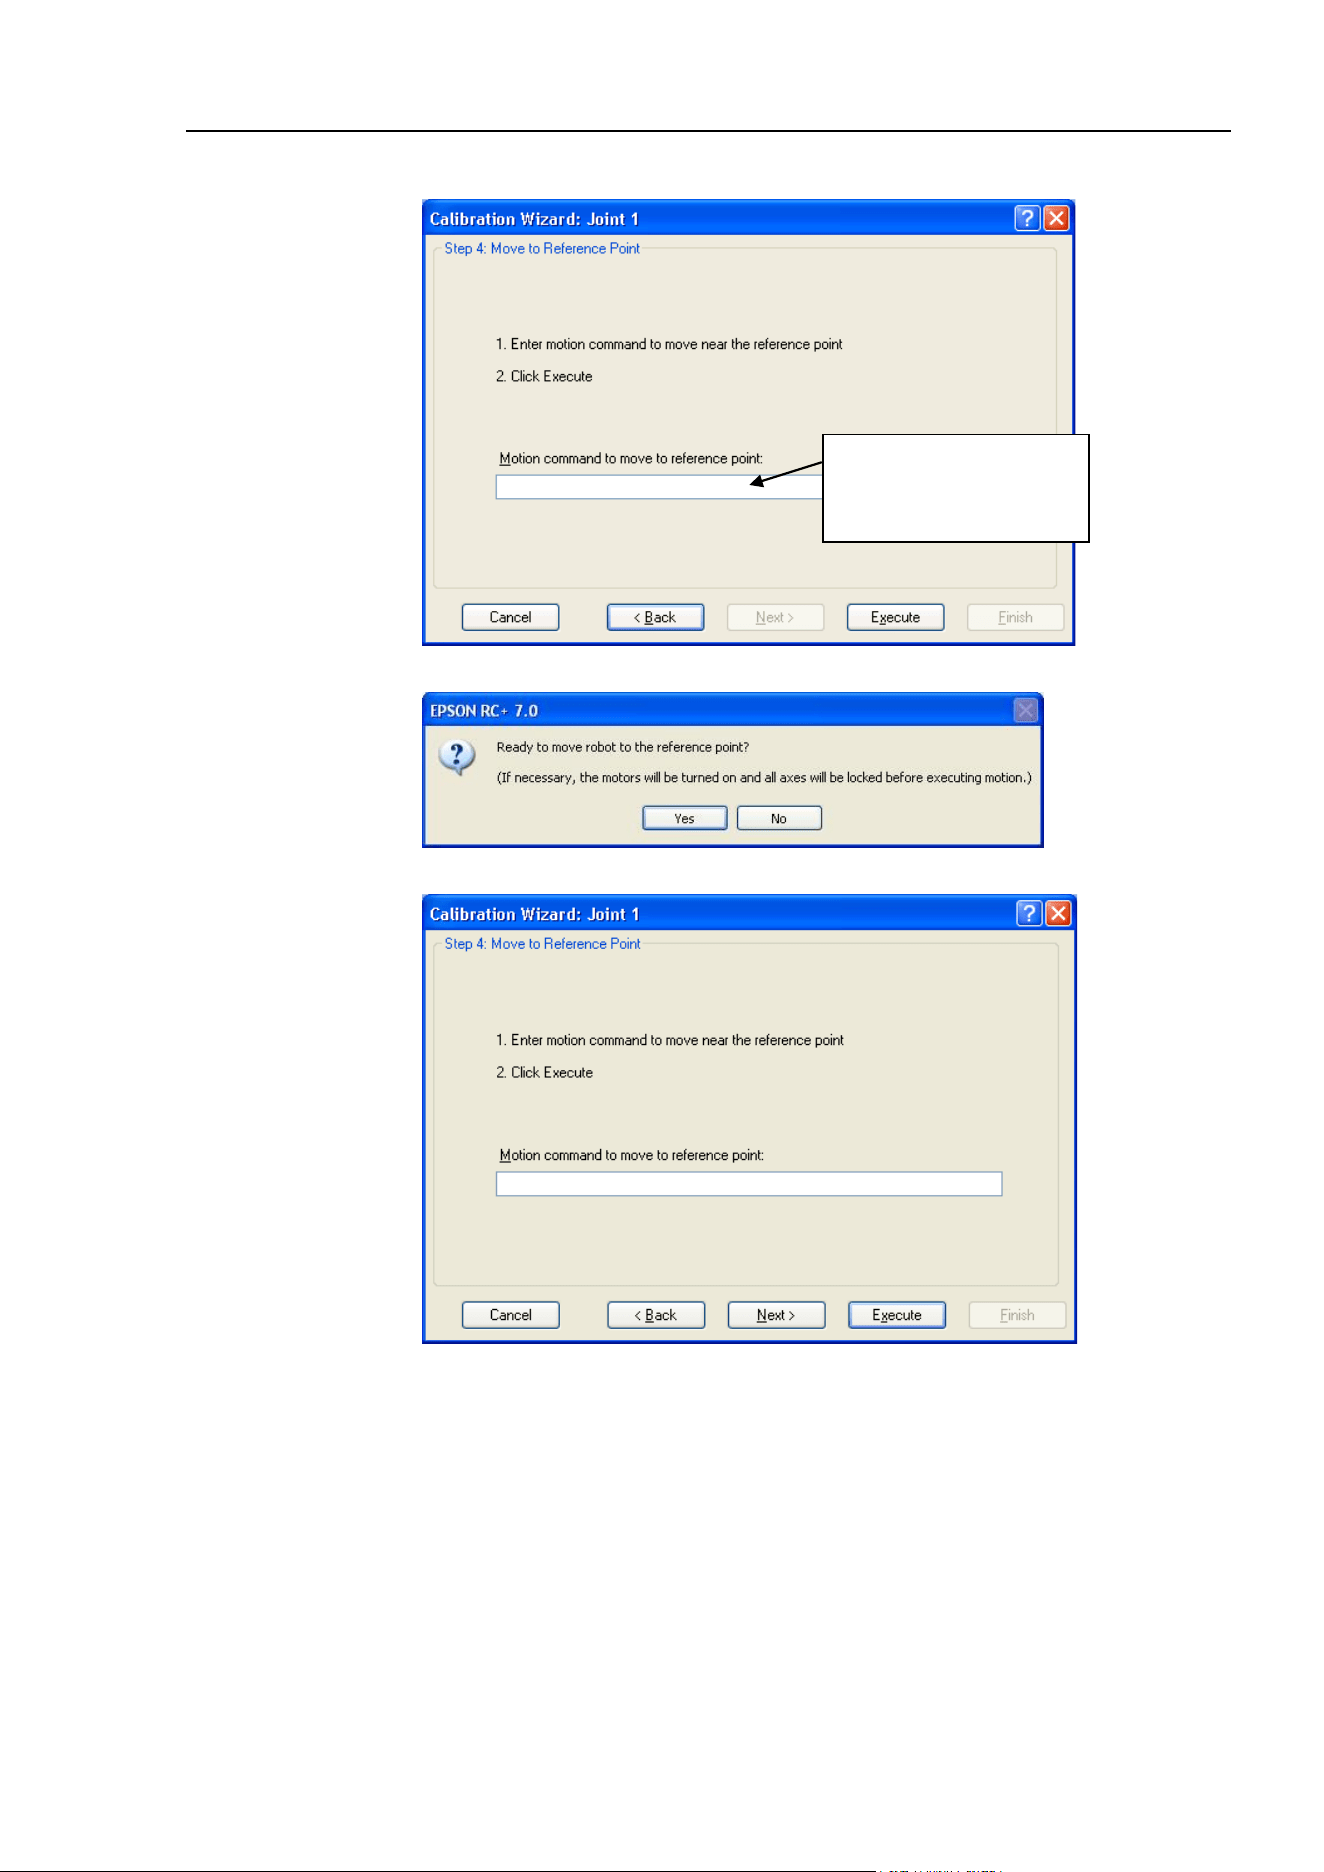
Maintenance 13. Calibration
LS20-B Rev.4 163
(10) The manipulator moves to the reference point. Click the <Execute> button.
Input JUMP P0:z(0).
↑
Point selected in step (6)
(11) Confirm the message and click the <Yes> button.
(12) After the manipulator moves to the reference point, click the <Next> button.
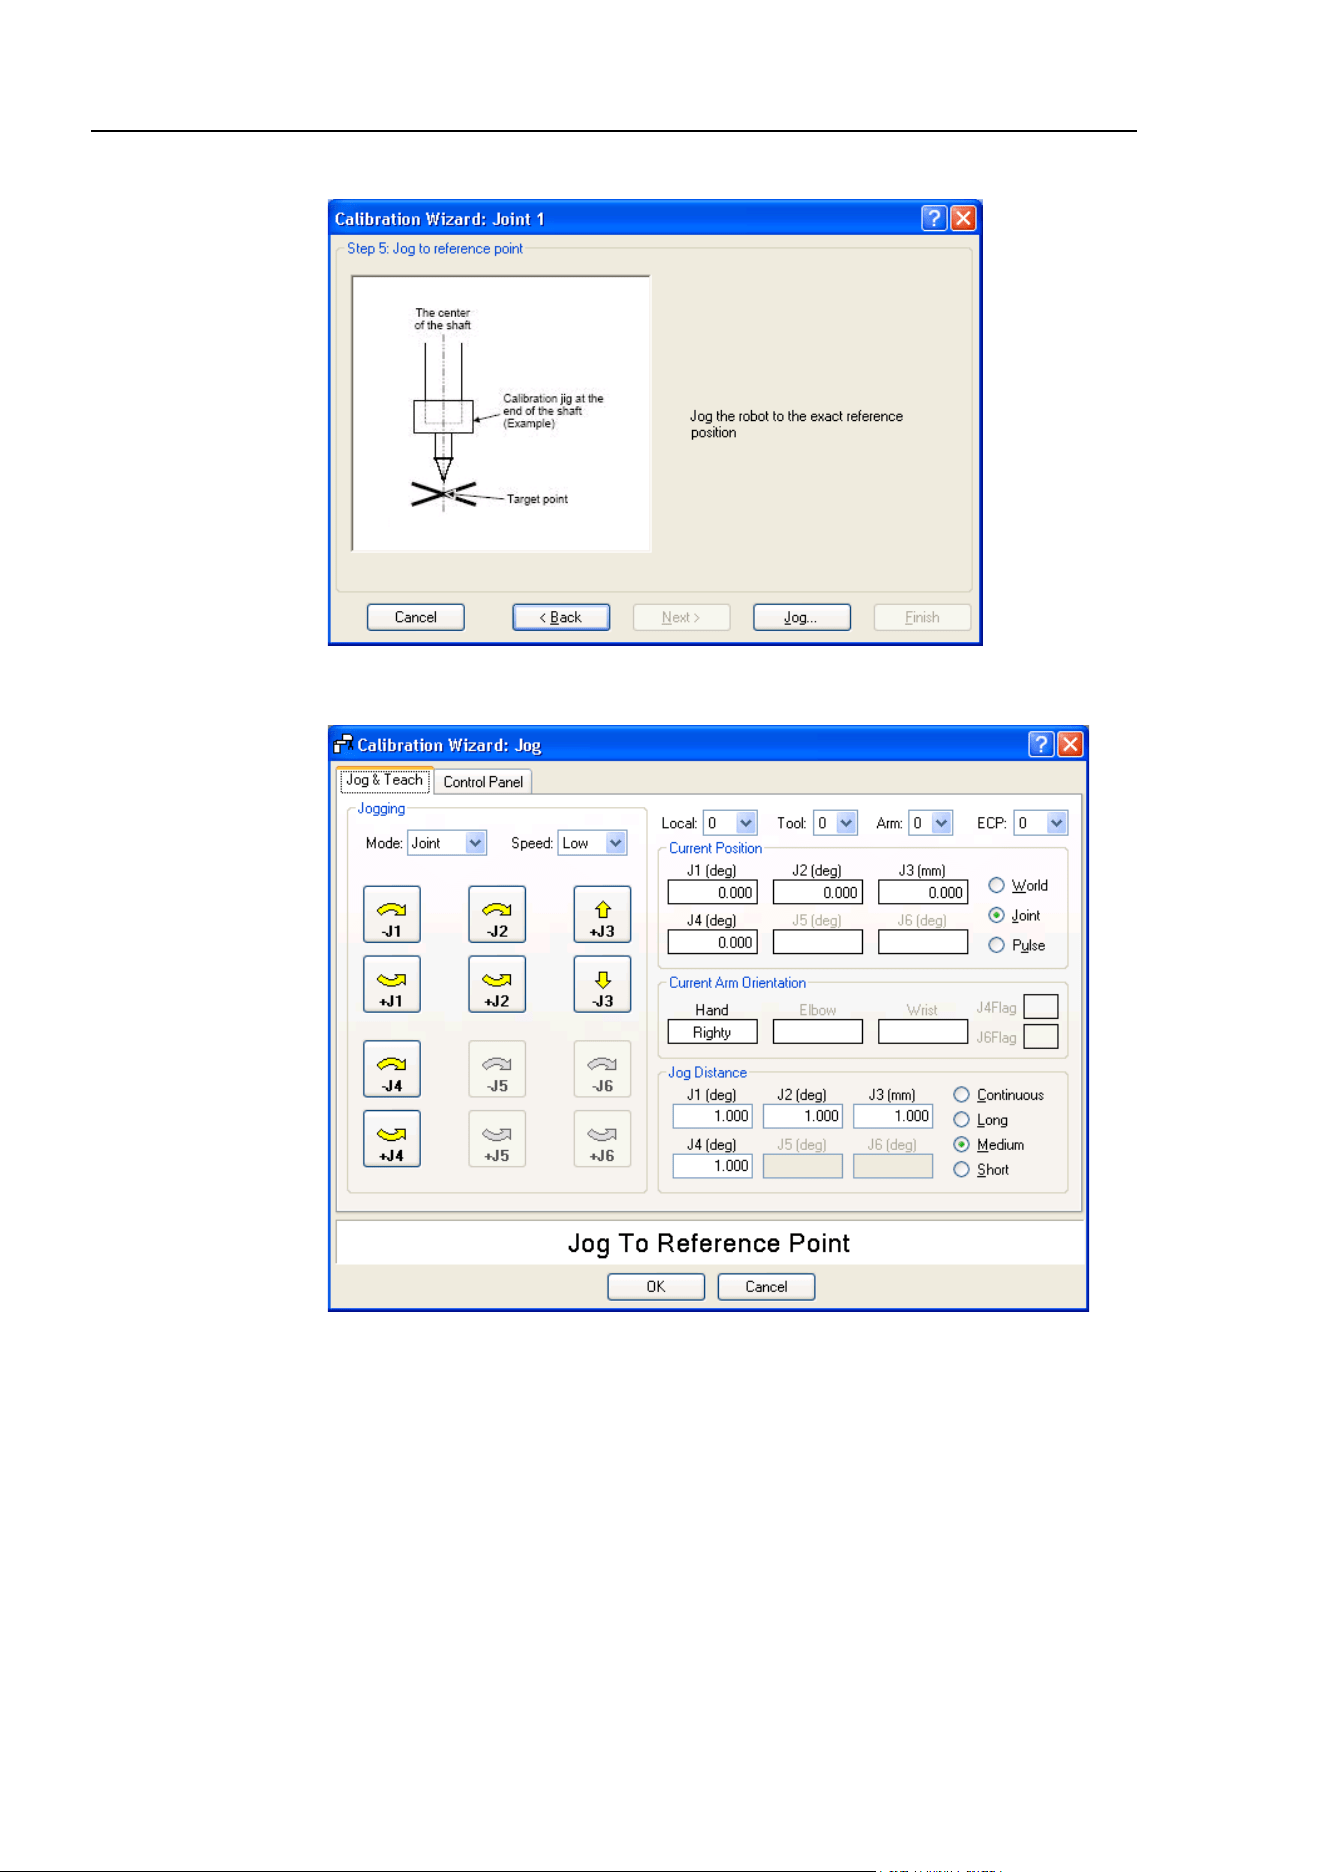
Maintenance 13. Calibration
164 LS20-B Rev.4
(13) Jog to the accurate reference position.
(14) Jog the end effector to approximate reference point in the [Jog & Teach] dialog for
rough calibration. Then click the <OK> button.
* Position Joint #2 only and move Joint #3 to around 0 pulse.
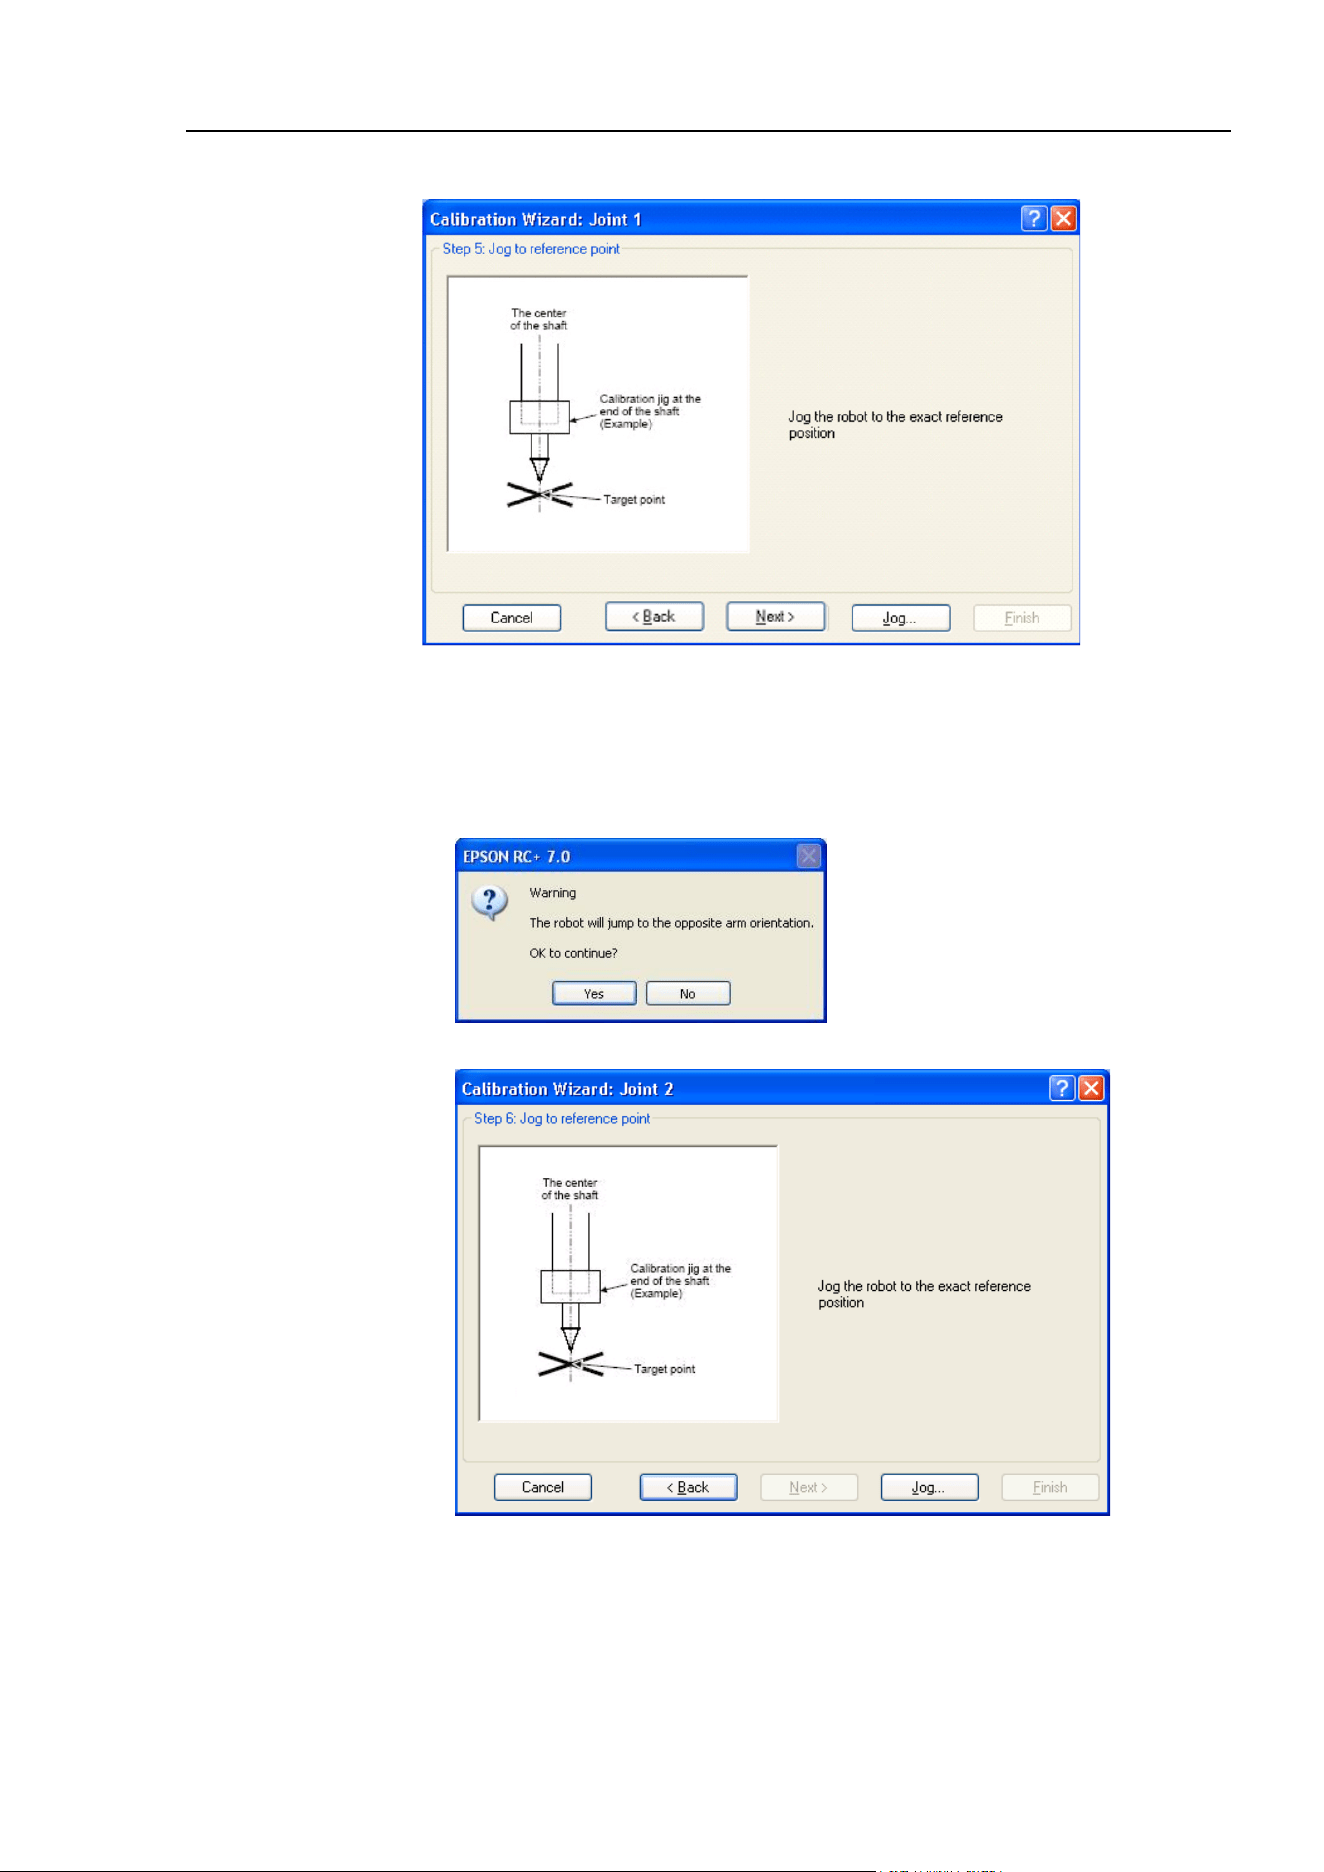
Maintenance 13. Calibration
LS20-B Rev.4 165
(15) Click the <Next> button.
(16) Execute the procedure in “Calibration Using Right / Left Arm Orientations” to
accurately calibrate Joint #2.
Go on to the step (17) for the other joints calibration.
i. Move to another point that has different pose (from righty to lefty) using Jump
command. Click the <Yes> button.
ii. Jog to the accurate reference position.
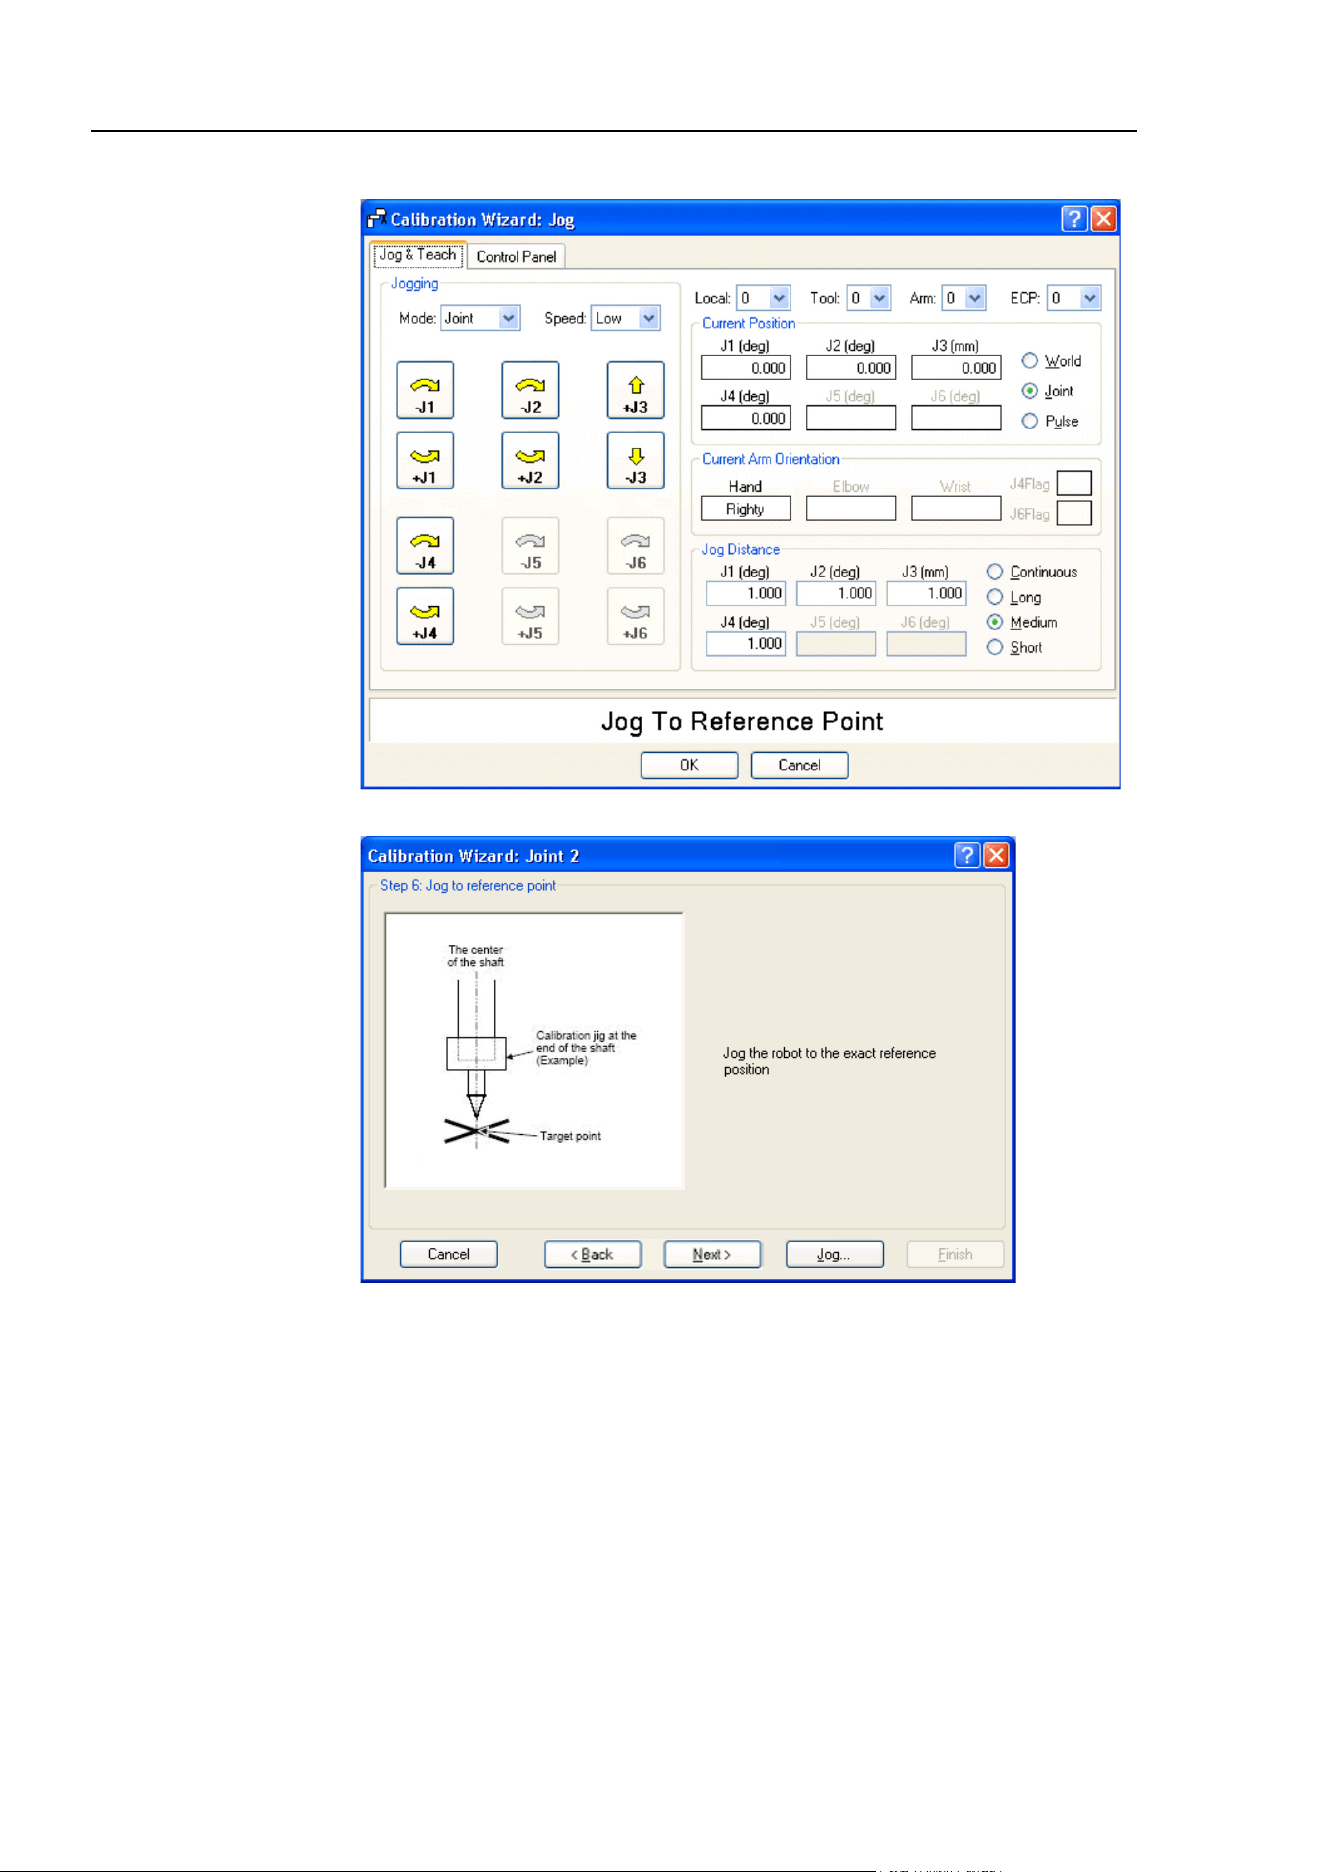
Maintenance 13. Calibration
166 LS20-B Rev.4
iii. Jog to the accurate reference position and adjust the position. Click the <OK> button.
iv. Click the <Next> button.
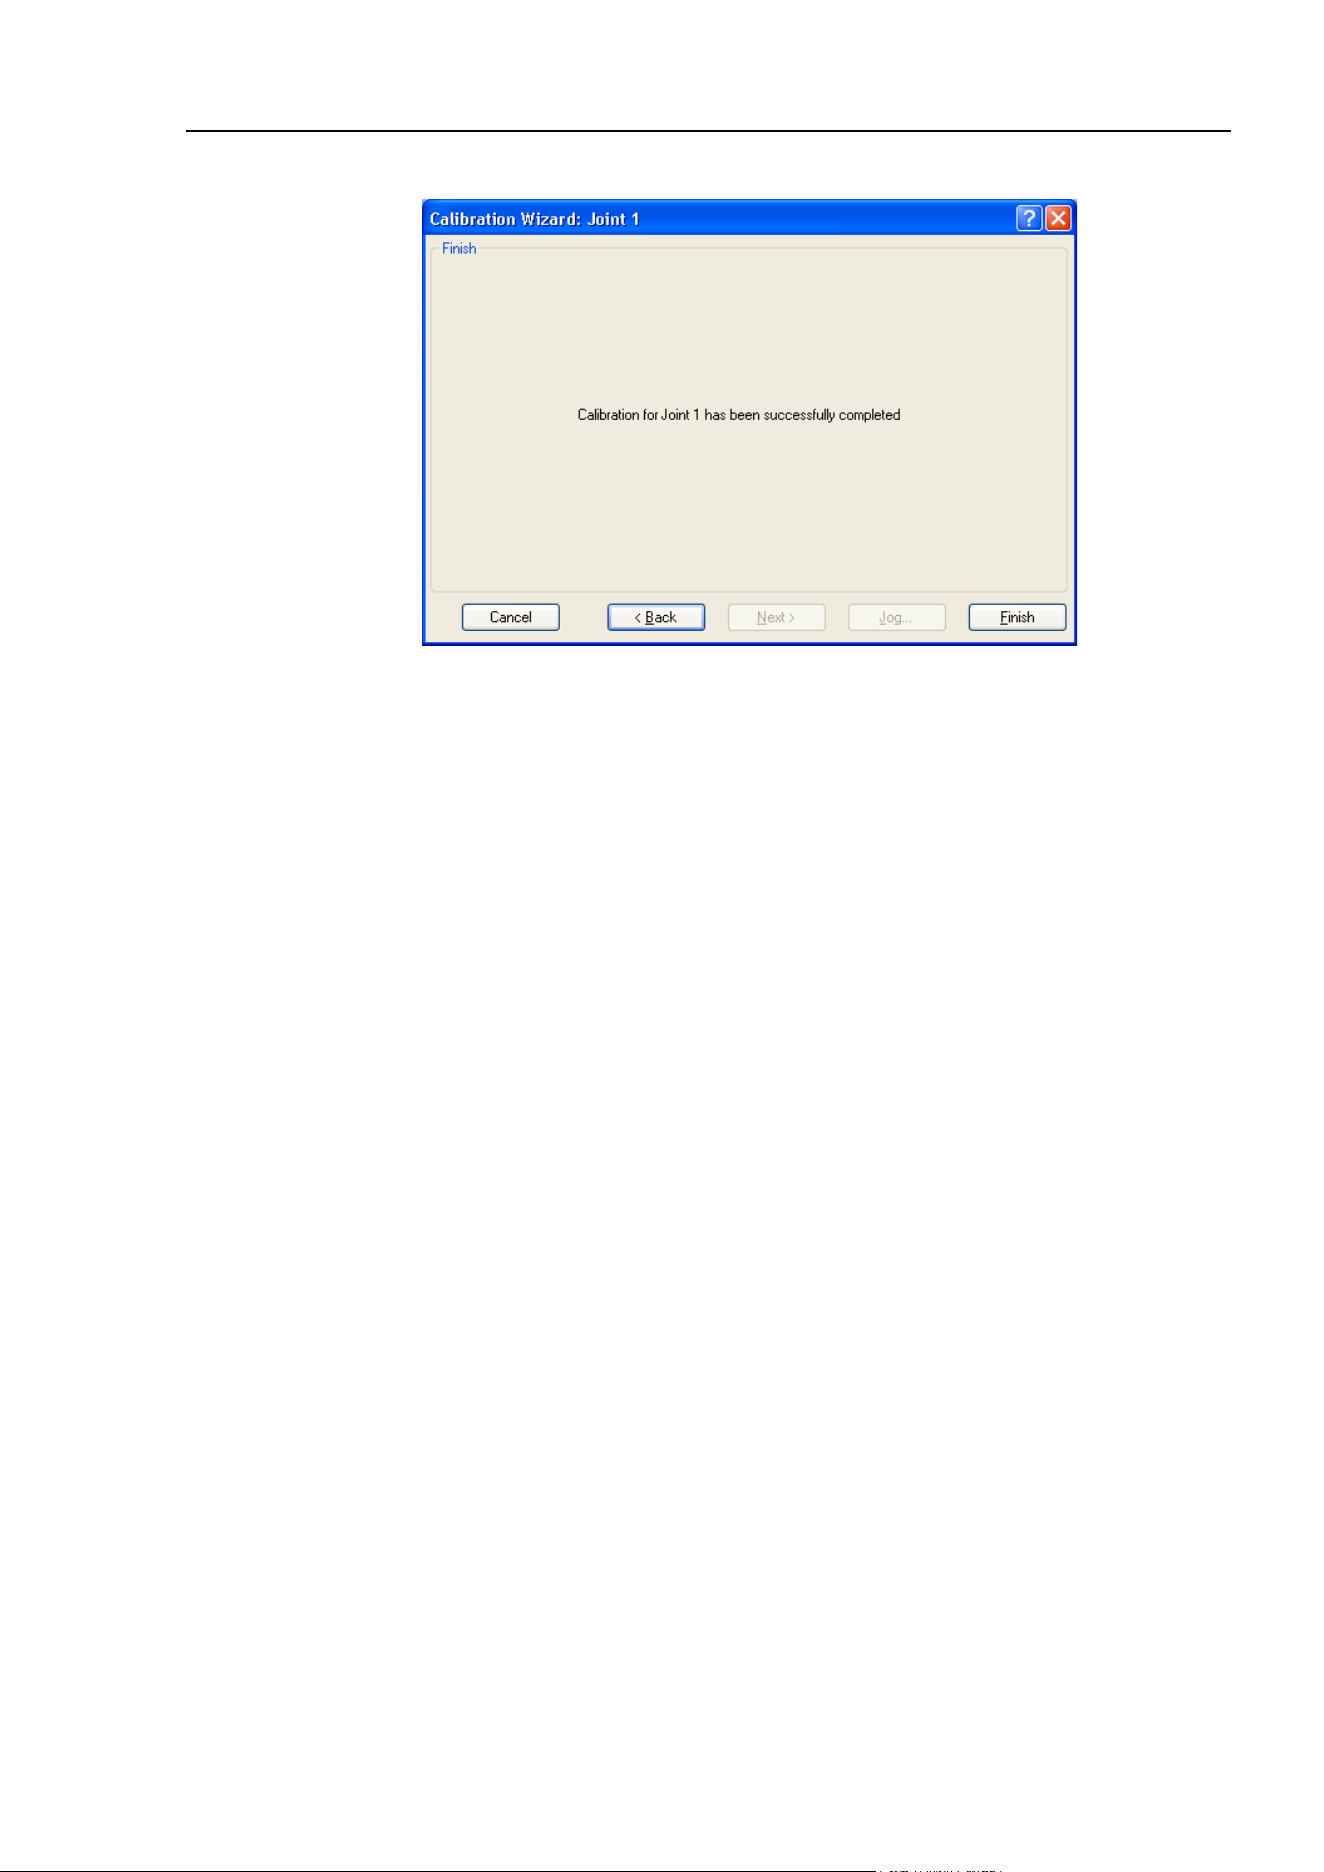
Maintenance 13. Calibration
LS20-B Rev.4 167
(17) Calibration is complete. Click the <Finish> button.
(18) Move the manipulator to other points and check if it can move without problems.
Teach points where appropriate.
Maintenance 13. Calibration
168 LS20-B Rev.4
13.3 Accurate Calibration of Joint #2
When coordinates for the Manipulator working point require calculation, it is important for
Joint #2 to be calibrated accurately.
If the accuracy of Joint #2 is not obtained through the steps in the section Maintenance: 13.2
Calibration Procedure, follow the steps below “Calibration Using Right / Left Arm
Orientations” to accurately calibrate Joint #2.
The
reference point is the center of the ball screw
spline shaft during this calibration.
When there is a misalignment between the center
of the end effector and the center of the ball screw
spline shaft, remove the end effector and execute
the calibration of
the shaft.
The center of the shaft
There is a misalignment
between the center of
the end effector and the
center of the shaft.
Make a calibration jig as shown in the right figure
and attach it on the end of the shaft to make the
center of the shaft clear.
Decide a target point and mark a cross (
×
) on it
so that you can easily verify the center of the
shaft after switching the arm pose between right
and left.
Calibration jig at the
end of the shaft
(Example)
Target point
The center
of the shaft
After removing the end effector and
executing the calibration
, install the end effector and
move the Manipulator to the teaching point to
verify whether there is a positional gap. If
there is a positional gap, fine
-
tune the installation position of the end effector and teach the
point again.
Coordinates for the working point requires calculation in the following cases:
· Teaching the working point by entering the coordinate values (MDI teaching)
· Switching the arm orientation between right and left at a given point
· Using the Pallet command
· Executing CP control (such as liner or circular interpolation)
· Using the Local command
· Pose data specified with relative coordinates <Example: P1+X(100) >
· Vision Guide camera calibrations
NOTE
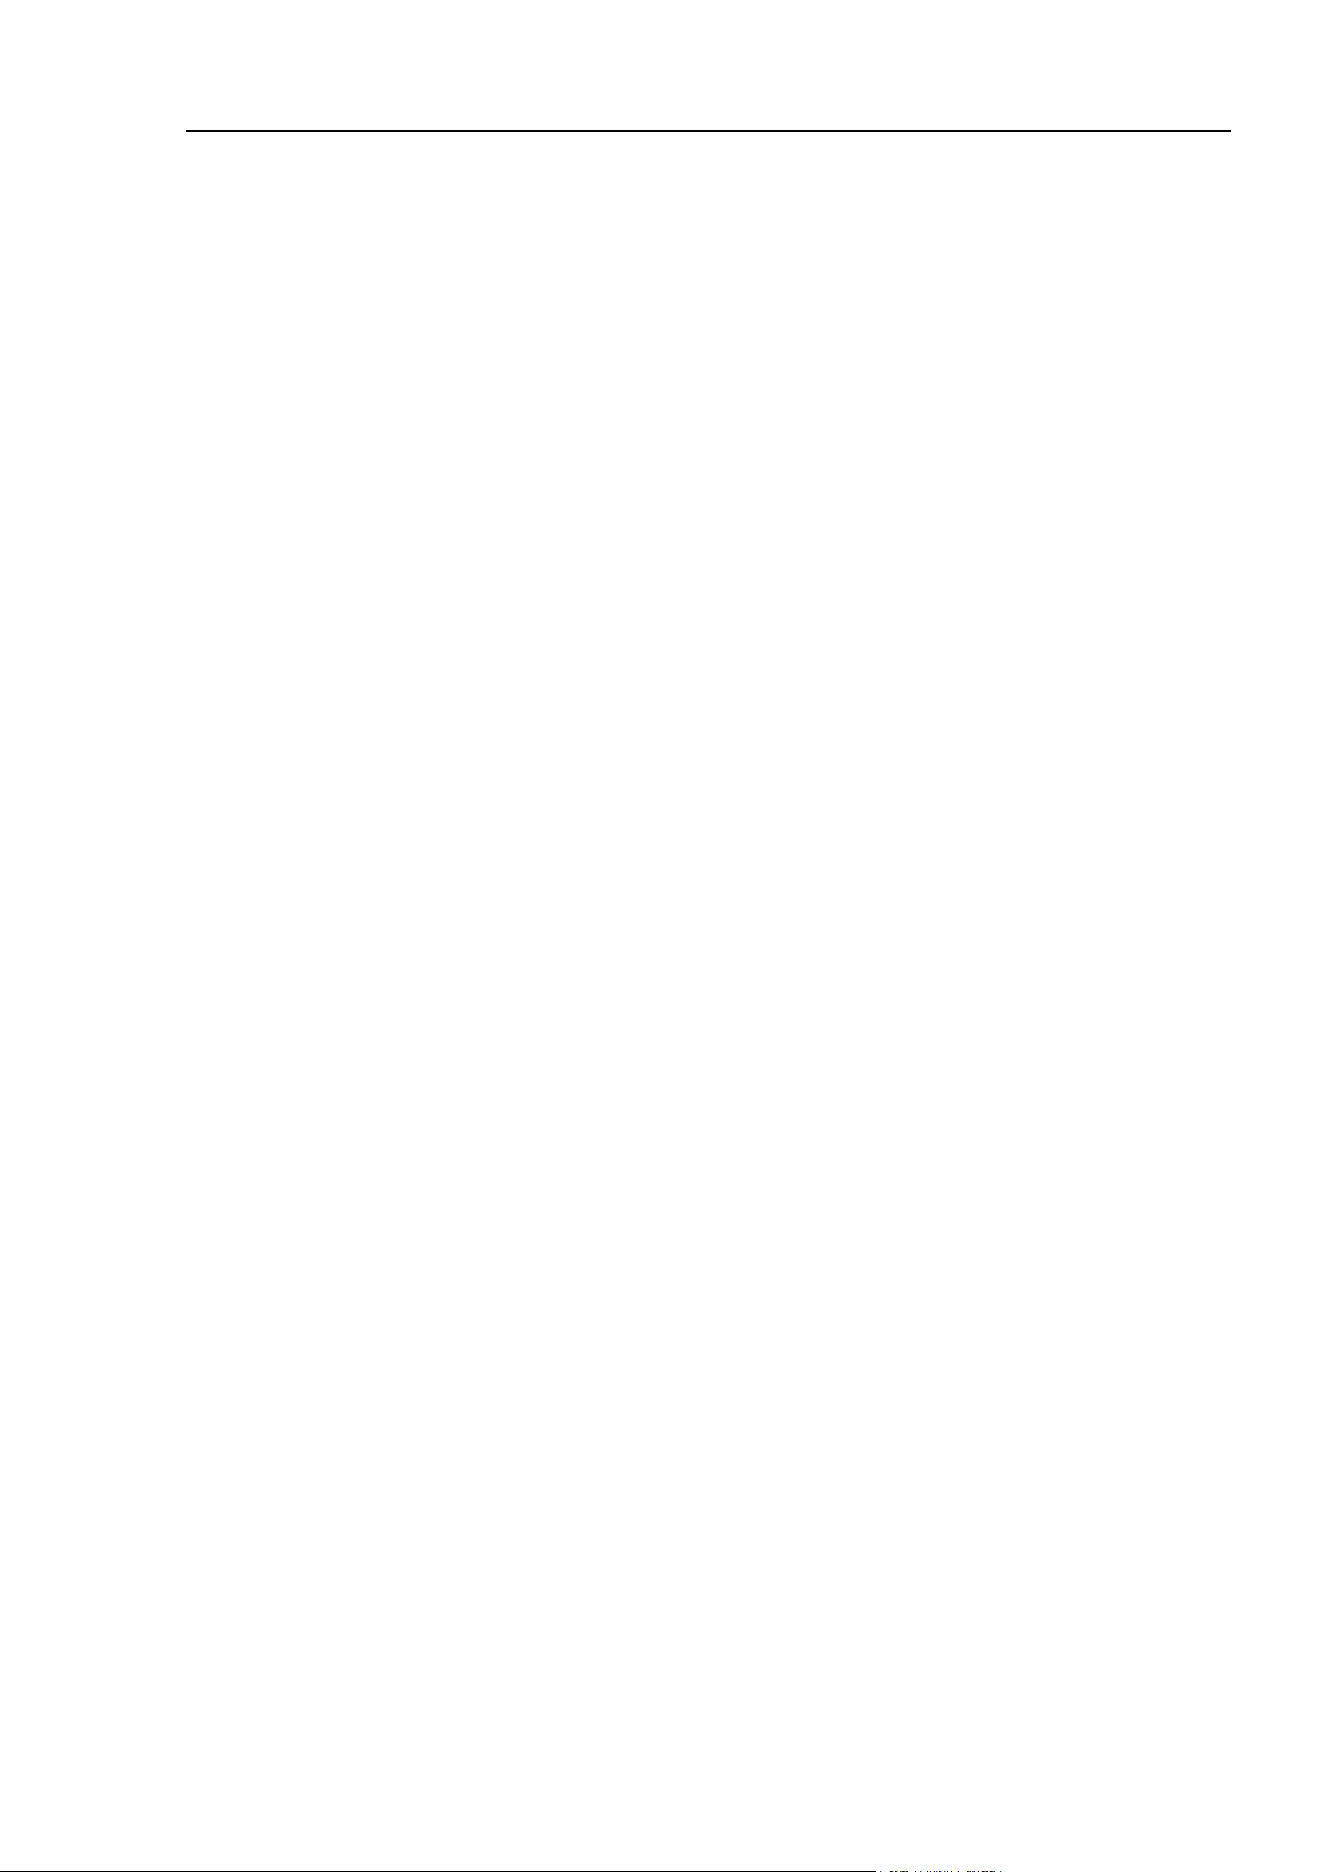
Maintenance 13. Calibration
LS20-B Rev.4 169
Calibration Using Right / Left Arm Orientations
(1)
Check the point data for calibration
Use
a point you can easily verify the accuracy within the work envelop of
both right
and left arm
. Then, check the number of points you want to use.
(2)
EPSON RC+ menu
-[Tools]-[Robot Manager]-[Control Panel] and
click the MOTOR
ON.
(3)
Click the
<Free All> button to free all joints from servo control. Now, you can move
arms by hands.
(4)
Move the arms to the position of point data for calibration in rightly arm orientation.
(5)
From the current position, teach any point data number unused.
This
point is now called P1.
Specify the point number
“1” and click the <Teach> button in the [Jog & Teach].
(6)
Click
the Lock All in the [Control Panel] to lock all joints under servo control.
(7)
Switch to the lefty arm orientation. Then, move the arm to the same point.
>Jump P1/L:Z(0) ' Change the arm orientation from righty to lefty
Z is the maximum position
* If there is interference on the way from right to lefty, click the
Free All in the
[Control Panel] and change the arm orientation to lefty by hands. Then, go to
the step (6), (7).
(8)
The joints are slightly out of position.
Adjust the gap with the
−
Z in the Jogging group in the [Jog & Teach]. Then, teach
another poin
t data number unused. This point is now called P2.
Specify point number
“P2” and click the <Teach> button in [Jog & Teach].
(9)
Input the new Hofs value.
>
Hofs Hofs (1), Hofs (2) + (Ppls(P1,2) + Ppls(P2,2)) /
2, Hofs(3), Hofs(4)
(10)
From the current lefty arm
orientation
(the position in the step (8)), teach the point data
number used in the step (8).
This point is called P2.
Specify point number
“P2” and click the <Teach> button in [Jog & Teach].
(11)
Switch to the righty arm orientation. Then, make sure the manipulator move to the
correct position.
>Jump P2/R ' Change the arm orientation from lefty to righty
* If there is any interference on the way from lefty to righty, click the Free All in the
[Control Panel] and change the arm orientation to righty by hands. Then, go to
the step (6), (11).
(12)
Move the manipulator to other point data and make sure it moves to the correct position.
Teach some more points if required.
* Delete the two points taught for the Joint #2 calibration.
Maintenance 13. Calibration
170 LS20-B Rev.4
13.4 Calibration Procedure without using Calibration Wizard
This section indicates the calibration without using the calibration wizard of EPSON RC+.
For details of calibration using the calibration wizard, refer to Maintenance: 13.2
Calibration Procedure.
When coordinates for the Manipulator working point require calculation, it is important for
Joint #2 to be calibrated accurately. Execute the procedure in “Calibration Using Right /
Left Arm Orientations” to accurately calibrate Joint #2. For details, refer to Maintenance:
13.3 Accurate Calibration of Joint #2.
You cannot calibrate Joint #4 alone because of the structure of the Manipulator. When
calibrating Joint #4, you must calibrate Joint #3 and #4 at the same time.
The reference point (a point to identify the position of the manipulator) needs to be specified
for calibration.
Follow steps
1 to 6 described below in order to calibrate the origin.
1.
Basic Pose Confirmation
(1
)-1 After the part replacement, execute the calibration using the
point data currently
registered.
Confirm the point data number (P*) to reconstruct the correct manipulator
position.
* Point data before the parts replacement
(motor, reduction gear, belt, etc.) is
necessary for the calibration.
2.
Part
Replacement
(2)
-1 Replace parts as dictated by this manual.
* Be careful not to injure yourself or damage parts during part replacement.
3.
Encoder Initialization
(3)
-1 Turn ON the Controller when all joints are in the motion range.
(3)
-2 Manually move the joint that needs origin alignment to its approximate 0
pulse position.
NOTE
NOTE
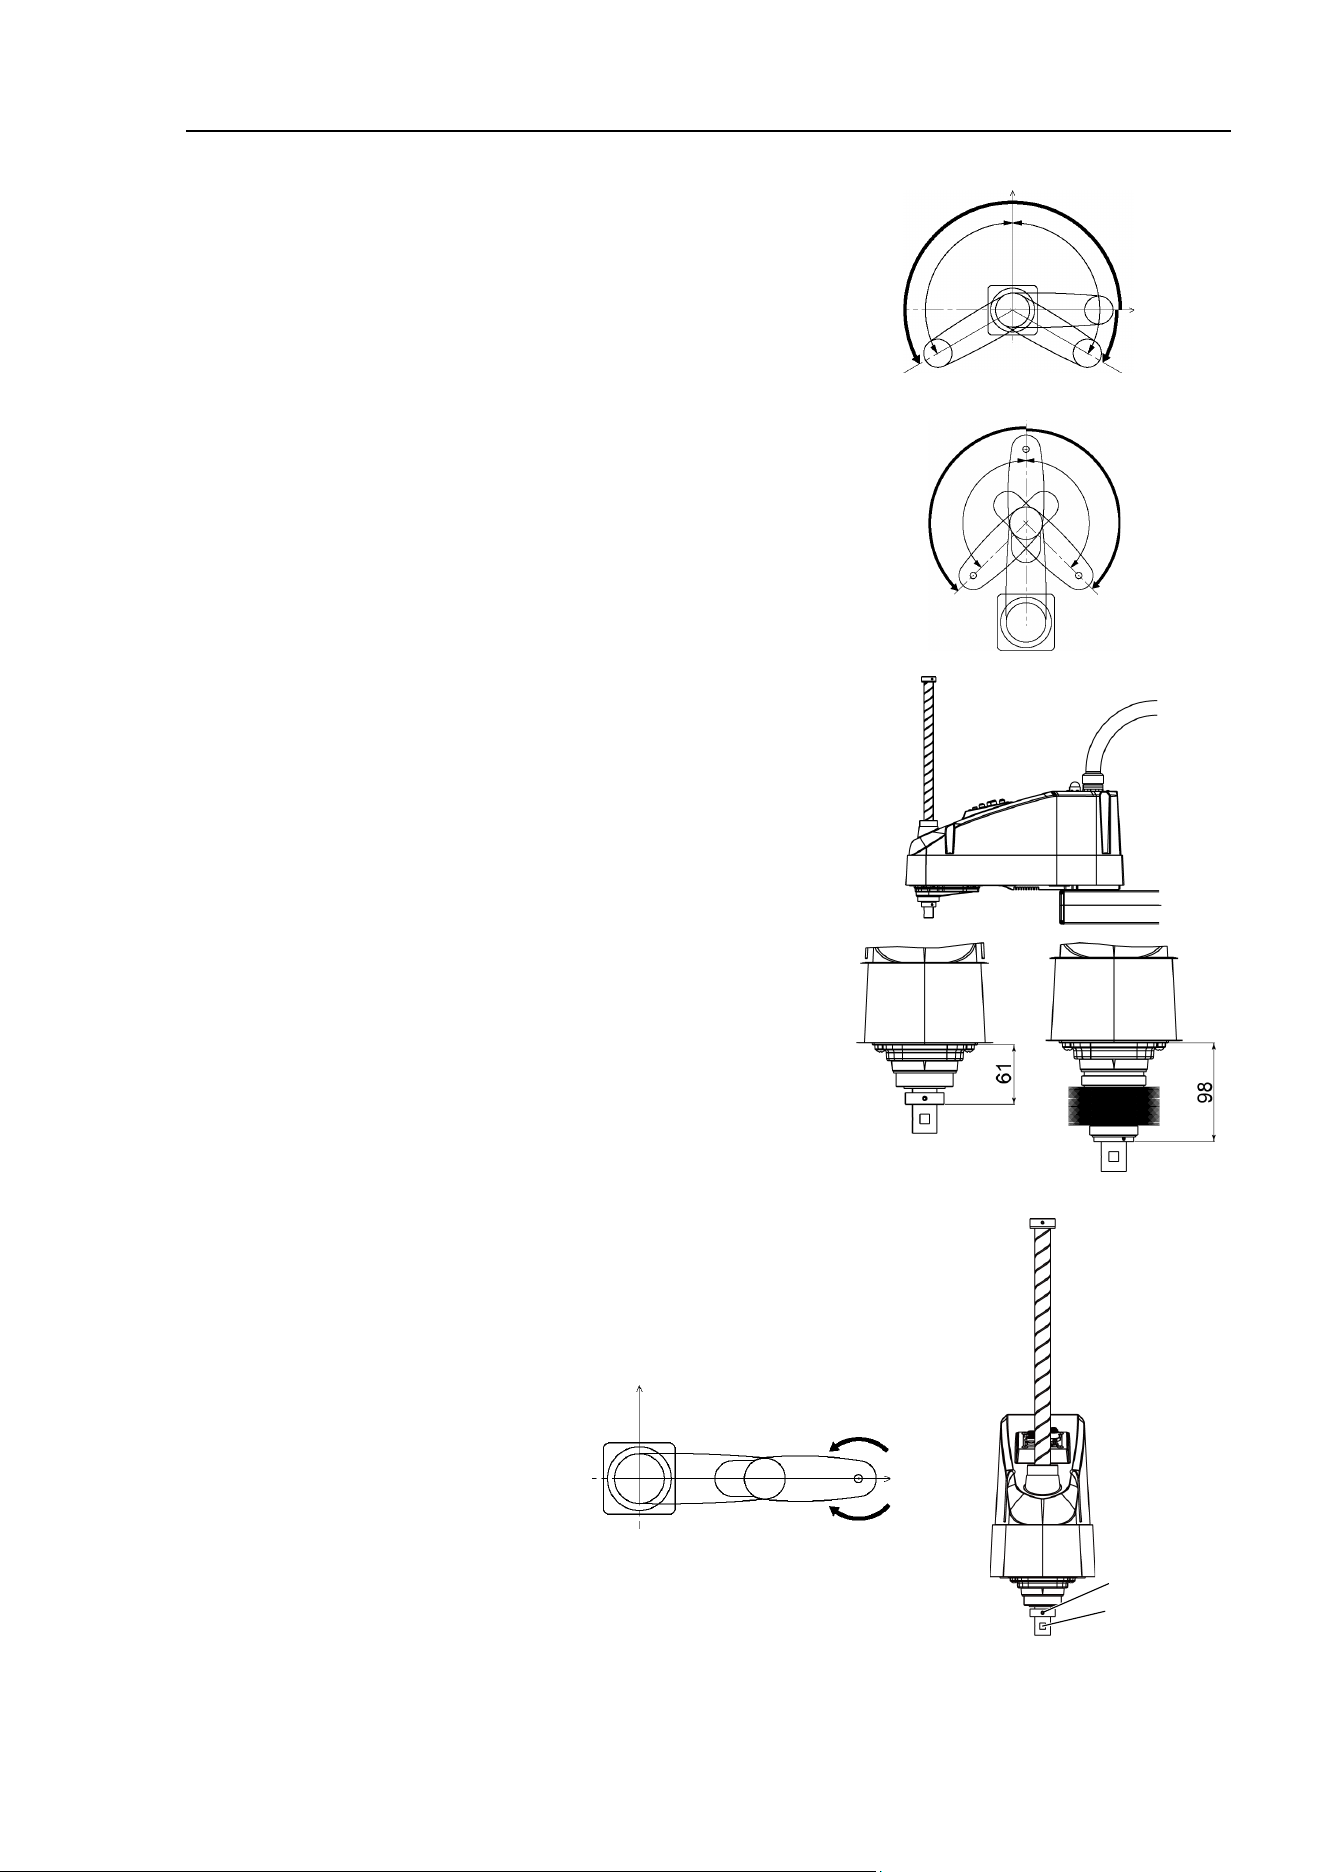
Maintenance 13. Calibration
LS20-B Rev.4 171
0 pulse position of Joint #1:
position aligned with X-axis in
Robot coordinate system
0 pulse
+
−
0 pulse position of Joint #2:
position where Arms #1 and #2
are in a straight line
(Regardless of the Joint #1
direction.)
0 pulse
+
−
0 pulse position of Joint #3:
upper limit position in motion
range
The height of Joint #3 depends
on manipulator model.
Standard model
Cleranroom model
0 pulse position of Joint #4:
position where the flat surface on the shaft (or
set screws of the mechanical stop on the
bottom) faces toward the tip of Arm #2
Flat Surface
Set Screws
0 pulse
+
−
Maintenance 13. Calibration
172 LS20-B Rev.4
(3)
-3 Connect EPSON RC+ to the Controller.
Select a robot to be calibrated. Input as below in the [Command Window]
and execute it.
(This example uses “robot 1”.)
> robot 1
(3)
-4 Execute the absolute encoder initialization command.
Input one of the following commands
to [Command Window] according to the
joint being calibrated.
Joint #1:
>EncReset 1
Joint #2:
>EncReset 2
Joint #3:
>EncReset 3
Joint #4:
>EncReset 3, 4
(3)
-5 Reboot the Controller.
Select EPSON RC+ menu-[Tools]-
[Controller] and click the <Reset
Controller> button.
This window will be disappeared when the Controller starts up.
4.
Rough
Calibration
(4)
-1 Execute the following command from the menu-[Tools]-[Command Window].
>calpls 0,0,0,0
* Manipulator does not move.
(4)
-2 Execute one of the following commands according to
the joint you want to
calibrate from the menu-[Tool]-[Command Window].
Joint #1 >calib 1
Joint #2 >calib 2
Joint #3 >calib 3
Joint #4 >calib 3, 4
5.
Calibration
(Accurate Positioning)
(5)
-1 Turn ON the motors from the EPSON RC+ menu-[Tools]-[Robot Manager]-
[Control Panel].
(5)
-2
Click the <Free All> button to free all joints from servo control. Now, you can
move arms by hands.
Maintenance 13. Calibration
LS20-B Rev.4 173
(5
)-3 Move the Manipulator by hand to a rough
position/posture of the calibration
point data.
(5
)-4 Create the data from the calibration point data.
Enter and execute the following command in [Command Window].
(In this example, P1 is used as the calibration point data.)
> Calpls Ppls(P1,1), Ppls(P1,2), Ppls(P1
,3),
Ppls(P1,4)
(5)
-5 Move the joint to the specified point using a motion command.
For example, when the specified point data is “P1”,
execute “Jump P1:Z(0)” from [Jog & Teach].
* The joint NOT being calibrated moves to the original position.
(5)
-6 Accurately align the joint* being calibrated to the specified point using
jog
commands.
* You must move Joint #3 and #4 to the position when calibrating Joint #4.
Select the jog mode [Joint] from [Jog & Teach] to execute the jog motion.
(5)
-7 Execute the calibration.
Enter and execute one of the following commands in [Command Window]
according to the joint being calibrated.
Joint #1:
>Calib 1
Joint #2:
>Calib 2
Joint #3:
>Calib 3
Joint #4:
>Calib 3, 4
6.
Accuracy Testing
(6)
-1 Move the Manipulator to another point to confirm that
it moves to the same
position.
If it does not move to the same position, re-calibrate using another point.
You
must set the point again
if reproducibility cannot be assured through calibration.
Maintenance 14. Maintenance Parts List
174 LS20-B Rev.4
14. Maintenance Parts List
Part Name Code Note
Reference:
Maintenance
Overhaul
*3
Cable Unit
LS20-B804*
2202239
800 mm
4.1 -
LS20-BA04*
2202240
1000 mm
AC Servo Motor
Joint #1
2202238
750 W
5.1
Joint #2
2197985
520 W
6.1
Joint #3
2197985
520 W
7.1
Joint #4
2197987
150 W
8.1
Reduction Gear
Unit *1
Joint #1
1646483
5.2
Joint #2
1798349
6.2
Joint #4
1493783
8.4
O-ring
Joint #1
1650902
For reduction gear unit
(Joint #1, Joint #2)
5.2 -
1489339
CO0557
1618362
CO0549
1618361
CO0546
Joint #2
1489339
CO0557
6.2 -
1618362
CO0549
Timing Belt
Joint #3
1618727
Z
7.2
Joint #4
1618729
U
8.2
Electromagnetic brake
1499588
Z-axis
7.3
1803965
U-axis
7.4
Brake Release Switch
2173869
-
-
Bellows
1499591
*4
9
-
Ball Screw Spline
LS20-B***S
1646487
420 mm
10.2
LS20-B***C
1646488
390 mm
Converter Board
2196970
11.1
-
Control Board
2196966
11.2
-
LED lamp
2077258
12
-
Grease *2
Ball Screw Spline:
AFB
-
For purchasing grease, and
adhesive, please the
supplier of your region.
10.1 -
Reduction Gear Unit:
SK-1A
5.2, 6.2 -
Arm Top Cover
1798943
White
3.1
-
Arm Bottom Cover
1759511
Blue
3.2
-
Dust Cover
2014430
For RJ45 connector
-
M/C Cable
2196934
3 m
4.3 -
2196935
5 m
2196936
10 m
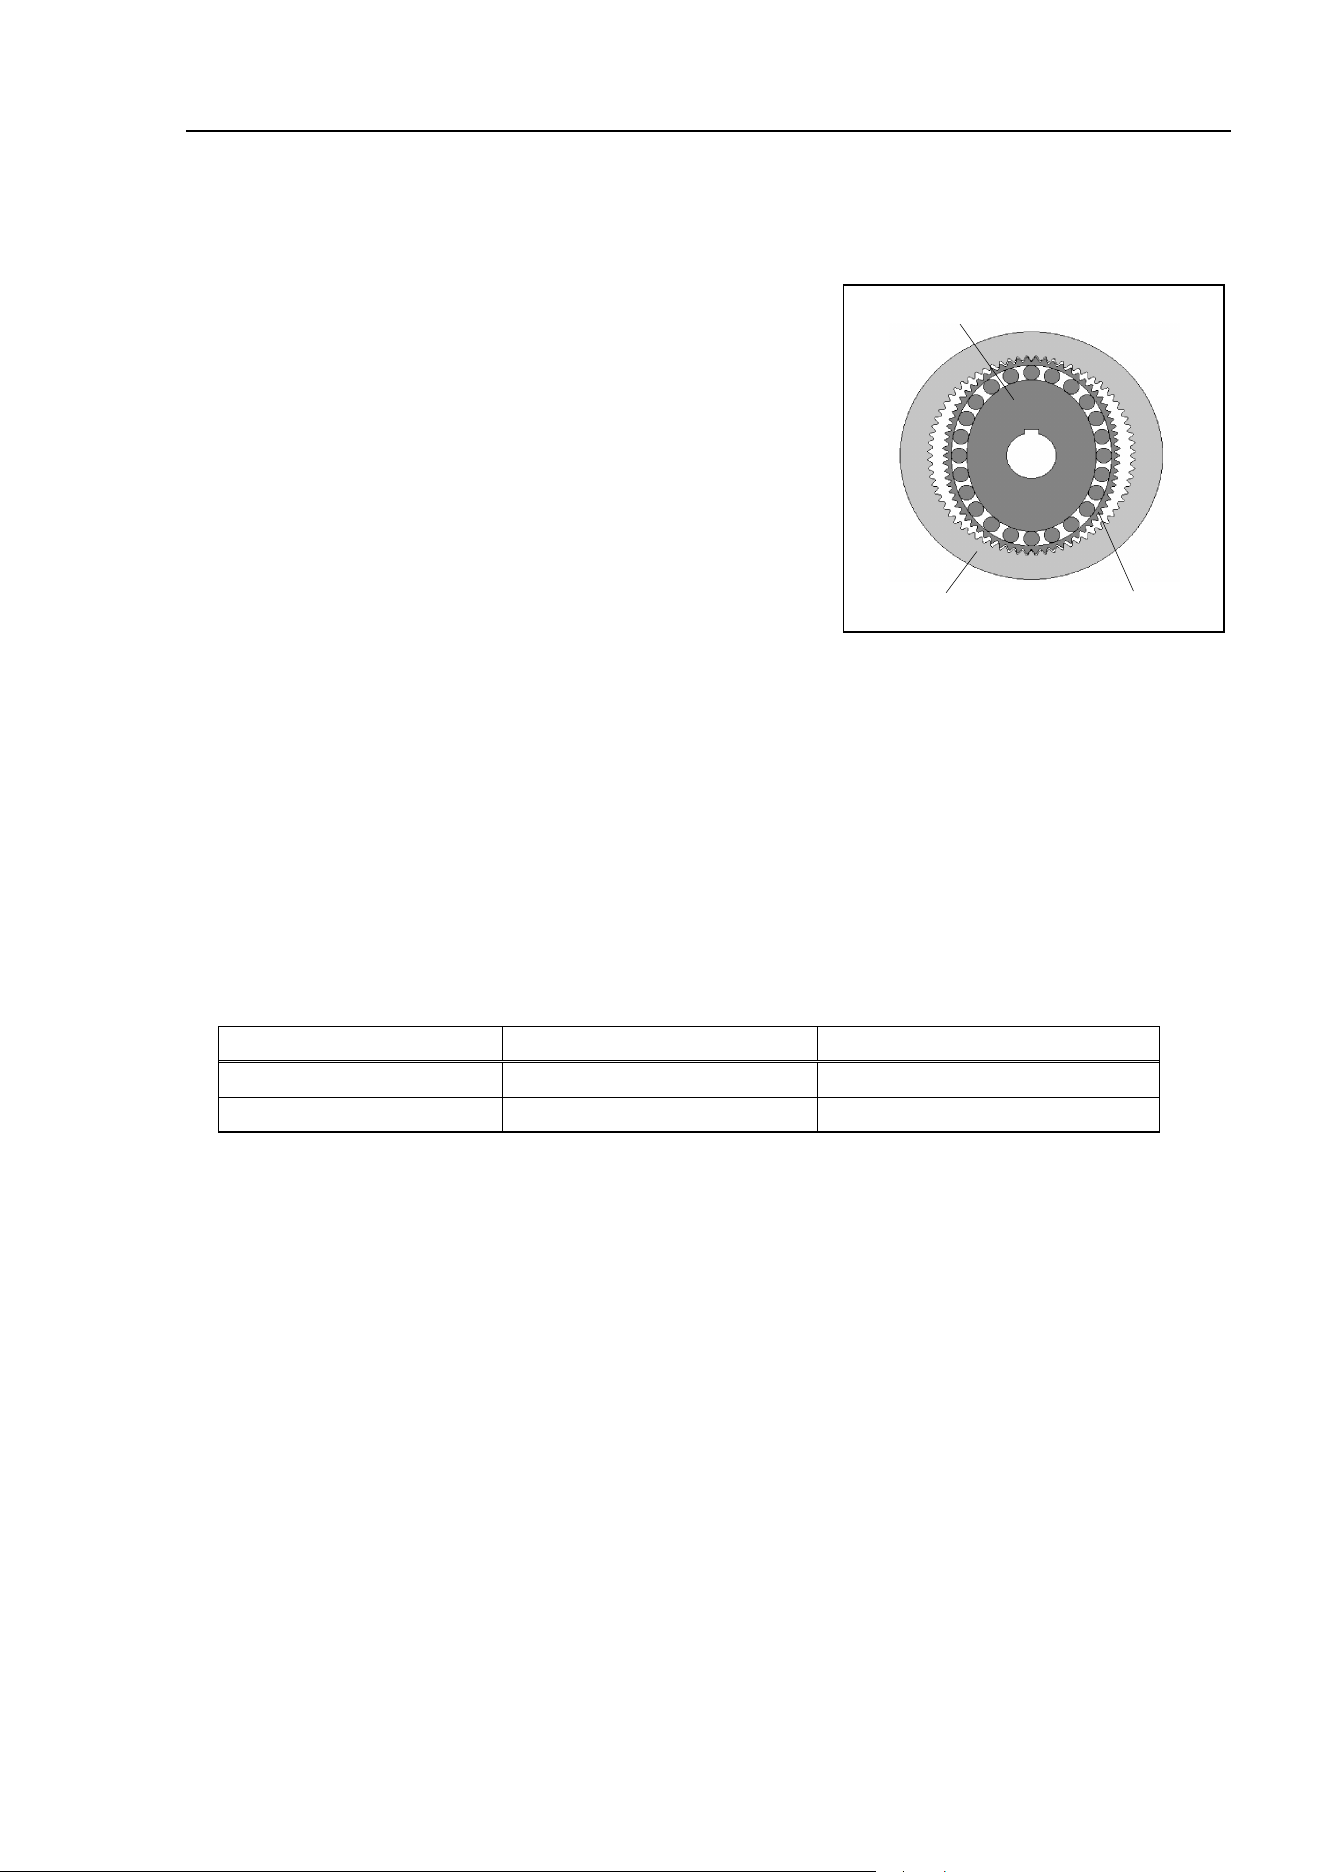
Maintenance 14. Maintenance Parts List
LS20-B Rev.4 175
*1 Reduction Gear Unit
A reduction gear unit consists of the following three parts. When replacing the reduction gear unit, be sure
to always replace the waveform generator, flexspline, and circular spline all together as one set.
Waveform generator
This waveform generator consists of an ellipsoidal cam with ball
bearings
on its outer circumference.
The inner ring of bearings is
secur
ed to the cam, while the outer ring
is capable of flexible deformation through the ball bearings.
Circular spline
Fle
xspline
Waveform generator
Flexspline
A thin, elastic, cup
-
shaped metal body with gear teeth around the
outer circumference of the opening.
Circular spline
A rigid, ring
-shaped body with gear teeth on the inner
circumference.
The circular spline has
two more teeth than the flexspline does.
Splines are greased. Be careful not to let grease adhere to clothes.
*2 Regarding purchase of grease
Due to the chemicals regulations of individual countries (the UN GHS), we are requesting our customers to
purchase the grease required for maintenance from the manufacturers listed in the table below as of April 2015.
Regarding purchase of the grease, please contact the following manufacturers. If there is anything unclear,
please contact the suppliers of your region.
Product name
Manufacturer
URL
THK AFB-LF Grease
THK CO., LTD.
http://www.thk.com/
Harmonic Grease SK-1A
Harmonic Drive Systems Inc.
http://www.harmonicdrive.net/
*3 Overhaul
As a rough indication, perform the overhaul (parts replacement) before reaching 20,000 operation hours of the
Manipulator. The operation hours can be checked in [Controller Status Viewer] dialog-[Motor On Hours].
For details, refer to Maintenance 2.2 Overhaul (Parts Replacement).
*4 Bellows
The bellows for LS20-B**C are provided in a unit of two pieces. The shape varies between the upper and
lower bellows.
Maintenance 14. Maintenance Parts List
176 LS20-B Rev.4